Lost notes [uts-0014]
Lost notes [uts-0014]
The following are normal leaf notes that are not transcluded by any note, and are not captured by root notes or Draft notes, thus might be lost.
Discussion. Differences along a line of sites [fdip-00AE]AGENTDRAFTED
- November 3, 2026
Discussion. Differences along a line of sites [fdip-00AE]AGENTDRAFTED
- November 3, 2026
On a line of sites the difference \(\varphi (x+1)-\varphi (x)\) is a linear function of the values of \(\varphi \). Written as a matrix, with one row for each step and one column for each site, it is the familiar bidiagonal matrix with \(-1\) and \(1\) in each row. The second difference on the sites is the transpose of that matrix multiplied by the matrix. The same array can be written for any finite carrier once an order of the sites and of the steps is chosen.
Remark. The Leibniz correction [fdip-00AO]AGENTDRAFTED
- November 3, 2026
Remark. The Leibniz correction [fdip-00AO]AGENTDRAFTED
- November 3, 2026
The cyclic shift \(T\) is translation by one site, and the forward difference \(\,(\Delta f)(i)=f(i+1)-f(i)\) is the derivative of spacing \(1\). The Leibniz rule \(\Delta (fg)=(\Delta f)g+f\Delta g\) fails by the extra product \(\,(\Delta f)(\Delta g)\). Lemma [fdip-0009] is the corrected identity, together with the indicator witness \(f^2=f\).
Why these notes connect polytopes and puzzles [frap-001E]AGENTDRAFTED
- October 9, 2026
Why these notes connect polytopes and puzzles [frap-001E]AGENTDRAFTED
- October 9, 2026
The motivation grew out of decades of playing the \(3\times 3\times 3\) cube, followed by the \(2\times 2\times 2\) and \(4\times 4\times 4\). Learning formulas raised questions about why they work, how different methods organize a solve, and how a computer might find a better solution. Those questions led back through group theory and the general \(N\times N\times N\) family to Marchetti's Rubik's Abstract Polytopes [marchetti2025rubik]. These notes deliberately reverse that journey: begin with general mathematics, develop increasingly concrete models, and return to solution methods and play with a deeper understanding of the familiar puzzle.
A first concrete question guides the route: when a turn acts on one facet, which positions move, and what incident labels travel with them? Starting with abstract polytopes lets us answer that question in two stages. We first record incidence and shape symmetry without choosing lengths or angles, then apply a local facet action and inspect its effect on a tetrahedron and a cube. This separation keeps the shape data distinct from the move data while giving each abstraction a visible puzzle consequence. Passing to layered cubes then asks how the pieces, their orientations and the allowed turns change with \(N\); the \(3\times 3\times 3\) cube provides a setting in which to work out the consequences in detail. Group actions connect these descriptions. They help us ask what a move changes, what a sequence preserves, which configurations are reachable, and how a solution can be assembled from smaller tasks. The additional structure in each model must be explained when the models are compared.
The return to solving has two closely related purposes. For a person, a useful formula connects a recognizable pattern with a manageable sequence of moves. Understanding its effect and what it preserves should help explain methods and the choices within a solve; recognition, memory and ease of execution matter alongside move count. For a computer, the question is how to find solutions under explicit objectives, including shortest solutions for a chosen set of moves and costs. Producing a solution, proving that a method solves every state in its domain, and establishing optimality are different achievements. Scrambling, replay and interactive exploration bring these questions back to actual use.
The puzzles also lead into mathematics beyond solving. Local orientation data raise questions about global constraints, wreath products and transfer. Transporting labels suggests comparisons with coloring obstructions and branched coverings [izmestiev2002branched]. Random scrambles and functions used to guide search lead to probability and representation theory [pan2021fourier]. These are directions for inquiry, with their own constructions and hypotheses; the aim is to understand the connections through examples and arguments as well as the puzzles themselves.
Scholarly sources, explicit calculations and formalization are meant to inform one another. Lean can express mathematical models and implement computations whose stated properties can be proved. Missing hypotheses or awkward conventions exposed by that work should feed back into the explanations here. FRAP is at an early research stage, and the companion repository does not yet contain a formalized puzzle model or solver.
A complete layer-first method [frap-0017]AGENTDRAFTED
A complete layer-first method [frap-0017]AGENTDRAFTED
The three-layer model in the complete cube account turns a human solve into a sequence of stabilizer problems. We keep the global viewing frame fixed and use its fixed local frame conventions. We write \(U,D,F,B,R,L\) for clockwise quarter-turns as seen from the named face. A prime is an inverse and a superscript \(2\) is a half-turn; a word is read from left to right. The bottom face \(D\) is the first layer, so its center fixes the target colour and the four side centres fix the cross alignment. The notation and face-view convention agree with the cube notation notes.
Effects, setup, and preservation
Effects, setup, and preservation
A slot is a destination for one corner or edge. A setup word \(s\) brings a chosen case to the working slot; a trigger \(t\) performs the local change there; and \(s t s^{-1}\) transports that change to another location. This is conjugation in the move group, not a promise that the transported word has the same visible support before the replay is checked. A commutator
\[ [a,b]=a b a^{-1}b^{-1} \]is useful when \(a\) and \(b\) overlap in a controlled way. Its support must still be computed in the current convention: cancellation in the group word does not by itself prove that every other piece is fixed.
Let \(H_i\) be the subgroup fixing everything completed before stage \(i\). A stage is valid when each of its words lies in \(H_i\) after the setup data have been restored. Thus a solve follows a descending chain
\[G\supseteq H_{\rm cross}\supseteq H_{\rm first}\supseteq H_{\rm middle}\supseteq H_{\rm last\,orientation}.\]The inclusions describe preservation, while the case table below gives the progress that makes the chain terminate. This separates the algebraic question “what does the word change?” from the practical questions of recognition, memory, and execution.
The complete seven-stage method
The complete seven-stage method
The following method is complete under the stated case conventions. At every stage, rotate only the working view or use a setup word; never rotate the whole cube while a positional convention is being recorded. A displayed algorithm is a witness for its local effect. Its inverse and a conjugate supply the other orientations and slots.
- Cross. Solve the four \(D\)-edges one at a time, matching each side colour to its centre. If a target edge is in the top layer, bring it above its slot and insert it with \(F^2\) or a quarter-turn setup. If it is in the first layer with the wrong orientation, eject it to the top and insert it again. Earlier cross edges are kept out of the working slot.
- First-layer corners. Put a target corner above its \(D\) slot at \(UFR\). Repeat \(T=R' D' R D\) until the target sticker faces down and the two side stickers match. The word \(T\) fixes the already solved cross after the setup is restored; at most four repetitions are needed. A corner incorrectly occupying the slot is first ejected with the same trigger, then treated as a top-layer case.
- Middle edges. With the solved layer on the bottom, align a top-layer edge with its side centre. To insert it on the right use \[I_R=U R U' R' U' F' U F,\]
- Last-layer cross. Ignore the side colours and orient the four \(U\)-edges with \[X=F R U R' U' F'.\]
- Last-layer edges. First restore the side colours of the four cross edges. The checked three-edge cycle \[P=R U' R U R U R U' R' U' R^2\]
- Last-layer corners. Put a correctly located corner at \(UFR\); if none is located, apply the word once and inspect again. The corner cycle \[C=R' F R' B^2 R F' R' B^2 R^2\]
- Last-layer corner orientation. Keep the cube fixed. At \(UFR\), repeat \(T=R'D'RD\) until that corner is oriented; turn only \(U\) to bring the next unsolved corner to \(UFR\), and repeat. During this stage the visible lower layers look disturbed, but after the last corner the accumulated orientation sum is zero and every earlier piece returns to its solved position.
and to insert it on the left use
\[I_L=U' L' U L U F U' F'.\]Both words restore the first layer. If a middle edge is misplaced, use either insertion to eject it, then solve the resulting top-layer case.
With the \(U\)-face viewed from above, a line is held horizontal and an L is held at the back-left. The same word changes the zero-, two-, or four-oriented-edge cases to a case with strictly more oriented edges after the indicated setup; repeat until the cross is present.
fixes the corners and cycles three \(U\)-edges. Together with a \(U\)-turn, its conjugates generate all permutations of the four cross edges: a 4-cycle and a 3-cycle generate \(S_4\). Apply a setup, one or more copies of \(P\) or \(P^{-1}\), and undo the setup.
fixes the cross edges and cycles the three other \(U\)-corners. Its conjugates and \(U\)-turns generate \(S_4\), so repeated applications place all four corners without changing their orientations.
The method uses only a small vocabulary of triggers. The setup words are the memory burden; each trigger has a recognizable local effect. The two places where an algorithm appears to disrupt completed material (the corner orientation stage and an ejection of a misplaced piece) are deliberate: the word is applied until the current local case is solved, after which the preservation invariant is restored.
Why the cases terminate
Why the cases terminate
We now justify completeness rather than infer it from successful demonstrations. A cross edge can always be moved to the top layer or ejected from its slot, and a quarter-turn or half-turn inserts it into a matching slot. Removing one solved edge leaves a connected set of unsolved slots, so four repetitions finish the cross. The corner trigger has a nonzero twist effect at \(UFR\) and fixes the cross after each full insertion; the eject-and-reinsert rule therefore solves four corners. The two middle insertions are inverses after reflection of the working view, and the same ejection argument solves four middle edges.
For the last layer, the edge-orientation word \(X\) changes the orientation pattern in the standard line/L/point cases while fixing both completed layers. The finite list of patterns has representatives point, line, and L; the prescribed setup makes the number of oriented edges increase, so the process reaches the cross. After orientation, \(P\) is a 3-cycle on edges and \(U\) is a 4-cycle. These generate \(S_4\), proving that the edge-position stage reaches every permutation. The analogous checked effect of \(C\), together with \(U\), gives \(S_4\) on corners.
Finally, \(T\) changes the orientation of the working corner while the temporary permutation cancels after the corner is finished and the next corner is brought into place. The corner orientation sum from the cube constraints is zero, so the final corner is forced when the other three have been oriented. Thus every state satisfying the three reachability tests has a finite word supplied by these stages. This is a completeness proof for the method, not an optimality claim.
One annotated local solve
One annotated local solve
Suppose the first two layers are solved, the \(U\)-cross is oriented, and the three-edge cycle needed to place the \(U\)-edge at the back is visible. Hold that edge at the slot to be fixed and apply \(P\); if the cycle runs the other way, apply \(P^{-1}\). The corners and all lower pieces return to their previous states. If the desired edge is not in the working support, choose a setup \(s\) that brings it there and replay
\[s P s^{-1}.\]After the edge positions are correct, use the same inspect--setup--cycle pattern for \(C\). Only then use \(T\) at \(UFR\), counting quarter-turns until the corner's \(U\)-sticker points up. The visible disorder during this last replay is expected; the final inverse setup and the orientation sum certify that the solved state has returned. This is the smallest complete trace of the method: recognize a case, transport a checked effect, and finish inside the next stabilizer.
A block-building or Roux-style organization can reduce the number of stages for an experienced solver, but it changes the recognition and preservation cases. It should be compared through the same questions—what is fixed, what subgroup remains, which effects are checked, and what is remembered—rather than by treating a lower move count as a complete measure of usability. The cube resource notes collect contrasting organizations for that later comparison.
A worked replay and projected lower bound [frap-001B]AGENTDRAFTED
A worked replay and projected lower bound [frap-001B]AGENTDRAFTED
The fixed-frame model has a concrete replay on a three-layer puzzle. Work in the fixed-frame HTM convention of the complete cube account: a face quarter-turn, its inverse, or a half-turn costs one move, and words are read from left to right. Start at the solved state and apply the declared scramble
\[w=R\ U\ R'\ U'\ F\ R\ U\ R'\ U'\ F'.\]The inverse word is
\[w^{-1}=F\ U\ R\ U'\ R'\ F'\ U\ R\ U'\ R'.\]A sticker-level replay of the six fixed-frame face maps sends the solved state to the recorded scramble state and then returns to solved. The check represents each of the 54 pairs in how the cube models connect as a slot, applies the six quarter-turn permutations and their inverses, and enumerates the projected corner states breadth first through depth two. The token-by-token states and hashes are preserved in the replay receipt. Running the tracked replay checker with `node scripts/check-frap-b9b.js trees/frap-001B-replay.json` reproduces and compares the stored `replay_log`. The complete cube account supplies the move convention; the replay, hashes and 262-state count are the deterministic calculation reported here. The second replay is therefore a certificate for the move convention and the inverse, not merely an animation of a familiar sequence.
What the small search certifies
What the small search certifies
Project the scrambled state to its corner positions and orientations. Exhaustive projected search finds 262 distinct projected states at depths zero, one, and two, while the target is absent; a projected distance of three is therefore a lower bound for this state. The declared word has ten HTM moves, so the same replay gives the bounded report
\[3\le d_{\rm HTM}(w,\mathrm {id})\le 10.\]The lower bound is admissible because projection forgets edge data and every full move projects to one projected move. The upper bound is a valid word because the inverse replay reaches the target. Neither bound claims that ten is shortest; a full optimality claim would need exhaustive search through depths four through nine or a matching certificate.
Relation to layer-first and computer methods
Relation to layer-first and computer methods
A player can recognize the displayed ten-move word as a repeated trigger pattern, but recognition is not a replacement for the state record. The complete layer-first method solves an arbitrary legal state by preserving completed layers and applying checked setup, trigger, and inverse-setup words; the computer account gives the corresponding upper-bound word and projected lower bound. This worked scramble shows how the two accounts meet: name the frame, replay the exact tokens, check the target, then state separately what has and has not been proved.
The example is deliberately bounded. It demonstrates a complete scramble-and-replay loop and a concrete comparison of certificates; it does not claim to be a full optimal solve, a universal human algorithm, or a replacement for the all-state completeness argument.
Computer solving and efficiency [frap-0018]AGENTDRAFTED
Computer solving and efficiency [frap-0018]AGENTDRAFTED
A computer solver answers a sharper question than a human method: from a recorded state, what is the shortest path to solved, or what short path can be found quickly? The answer depends on the move metric, the state coordinates, and the information retained by the search. We use the fixed-frame ordinary 3-layer action from the complete cube account, with the six outer face turns as generators. The methods chapter supplies the group-action graph viewpoints; here they become finite search procedures.
Move graphs and lower bounds
Move graphs and lower bounds
For a move metric \(M\), let \(\Gamma _M\) be the undirected graph whose vertices are legal cube states and whose edges apply one allowed move, with each edge weighted by that move's cost in \(M\). A graph distance is the function
\[d_M(x,y)=\text {the minimum total edge weight on a path from }x\text { to }y.\]The metric diameter is the maximum of \(d_M(x,y)\) over legal states; in a transitive move graph it is also the maximum distance from the solved state. For unit-cost moves, breadth-first search from solved labels every reachable vertex by exact distance, because the first time a vertex is reached there is no shorter path left in the earlier layers. With non-unit weights, Dijkstra's algorithm supplies the analogous exact labels. A depth-first method can use the same graph without storing all of it; optimal branch-and-bound and IDA* need a certified lower bound to prune safely.
The usual half-turn metric (HTM) charges each face quarter-turn, inverse quarter-turn, or half-turn one move. The quarter-turn metric (QTM) charges a half-turn two moves. A word can therefore be shorter in HTM while representing the same group element; an efficiency claim is incomplete until its metric and move set are named.
A simple counting bound already separates search from proof. In HTM there are at most eighteen first moves and at most seventeen choices after the first if an immediate inverse is suppressed. Hence a ball of radius \(r\) has at most
\[1+18\sum _{i=0}^{r-1}17^i\]vertices. The reachable 3-layer state count from the complete cube account is
\[N_3=8!\,12!\,3^7\,2^{10} =43\,252\,003\,274\,489\,856\,000.\]The corresponding upper estimate for a radius-15 ball is
\[1+18\sum _{i=0}^{14}17^i =3\,220\,225\,932\,948\,542\,767<N_3.\]Thus not every state can lie within fifteen moves, so the HTM diameter is at least \(16\). This is only a counting lower bound: it does not exhibit a state at distance sixteen, and it says nothing about a particular scramble.
One exact small search
One exact small search
The same procedure can be made exhaustive on the corner-only cube. In a fixed-frame labelling (there are no centers on a \(2\times 2\times 2\)), a legal state is a corner permutation together with seven independent twists, so there are
\[8!\,3^7=88\,179\,840\]labelled states. Quotienting by the twenty-four orientations of the whole cube leaves \(3\,674\,160\) rotation classes. Enumerate the six face quarter-turns, their inverses, and the six face half-turns; canonicalize each state by the whole-cube rotation action, and keep the first depth at which each rotation class is seen. The resulting layer sizes in HTM are
\[1,9,54,321,1847,9992,50136,227536, 870072,1887748,623800,2644.\]They sum to \(3\,674\,160\); the last nonempty layer is \(11\). Thus this finite breadth-first computation proves that the rotation-quotient corner-only cube has diameter eleven in HTM. It is an exact search: every rotation class is covered and every recorded depth is a shortest distance. The calculation agrees with the published exhaustive layer table for the pocket cube, p. 3. The calculation also illustrates why the full 3-layer graph is not attacked by naïve BFS: its state count is larger by many orders of magnitude.
Admissible heuristics and pattern databases
Admissible heuristics and pattern databases
A projection heuristic forgets part of a state. If \(\pi \) maps the full move graph to a smaller graph and every full move projects to a projected path of no greater total cost, then
\[h_\pi (x)=d_{\pi }(\pi (x),\pi (\mathrm {id}))\]never overestimates the full distance: projecting a full solution gives a projected solution of no greater cost. For example, a table entry \(h_\pi (x)=2\) certifies that every full solution from \(x\) costs at least two. Such a function is an admissible heuristic. A maximum of admissible heuristics is admissible; a sum needs an additional cost-partition argument and is not automatically safe. The graph maps here are specified by these equations and move lists, so a separate vector diagram would add no state or cost data.
A pattern database stores these projected distances in a table indexed by a selected set of cubies or coordinates. Reverse breadth-first search fills the table once; an iterative-deepening A* (IDA*) search then explores depth thresholds while pruning a node \(x\) whenever \(g+h_\pi (x)\) exceeds the threshold. Korf's Rubik's-cube computation used this combination of pattern databases and IDA* for optimal solutions to random instances the AAAI paper, abstract and sections “Problem Space” and “Pattern Databases”. The table certifies a lower bound, while the exhaustive threshold search is what certifies optimality.
For the 3-layer coordinates, a corner-orientation table has \(3^7\) entries, an edge-orientation table has \(2^{11}\), and a chosen edge-position table can be indexed separately. Taking the maximum of their exact projected distances is safe and often much stronger than either table alone. Memory, lookup cost, and the number of expanded nodes are measurable resources; none of them changes the definition of the shortest distance.
Subgroup reduction and two phases
Subgroup reduction and two phases
A different compression searches through a goal subgroup. Let
\[G_1=\langle U,D,R^2,L^2,F^2,B^2\rangle .\]In this subgroup the corner and edge orientations are fixed, and the four middle-slice edges stay in their slice. A first phase searches the full generator set for a word taking the scramble into \(G_1\); a second phase solves inside \(G_1\) using only its generators. The phase-1 coordinates are corner orientation, edge orientation, and the choice of the four slice edges, with raw size
\[3^7\,2^{11}\binom {12}{4}=2\,217\,093\,120.\]Pruning tables and symmetry reductions store only useful projections of this space.
Kociemba's two-phase account describes IDA* over these coordinates and explicitly distinguishes a fast near-optimal solver from an optimal solver the Phase 1, Phase 2 and optimality paragraphs. A solution found by one phase-1 word followed by a phase-2 word is a valid upper bound. It becomes a proof of optimality only when every shorter possibility under the declared metric has been excluded. Restricting phase two to \(G_1\) makes the search practical, but can omit an overall shortest route that leaves and later re-enters \(G_1\).
This reduction is the computer analogue of the preservation chain in the complete layer-first method: both deliberately fix information before solving what remains. The difference is the certificate. A human stage records a finite case argument; a search stage records a lower bound, an upper-bound word, and the unexplored threshold.
Efficiency and growing cubes
Efficiency and growing cubes
A useful report separates four measurements: solution length in a named metric, number of expanded nodes, peak table memory, and wall-clock time on named hardware. Recognition and move execution belong to the human method; node expansions and table construction belong to the computer method. A shorter returned word is evidence of a better upper bound, not by itself a proof that the word is shortest.
For the growing \(N\times N\times N\) family, the asymptotic question is how the diameter changes with \(N\) when a move rotates one legal slice. Demaine, Demaine, Eisenstat, Lubiw and Winslow prove a scoped result for this family: the diameter is \(\Theta (N^2/\log N)\), with a counting lower bound and a parallelized upper-bound construction their abstract and Section 2, “Common Definitions”. Their model allows a legal slice rotation as defined there; that move convention must be checked before transferring the statement to a different layered-cube convention.
The fixed-frame 3-layer count and the exact corner-only search give two finite anchors for that asymptotic discussion. The asymptotic theorem does not make a particular 3-layer word optimal, and the exact small search does not predict the table size or diameter of larger cubes. Across all sizes, correctness means reaching the target; optimality means proving a shortest path; efficiency means reporting the resources used to obtain either one.
Computer solving therefore extends the earlier construction in three controlled directions: exact graph distances on a small quotient, admissible lower bounds for the full state space, and subgroup reductions that trade completeness of the search for speed. These distinctions let a later return to play report a solver's output without confusing a valid solve, a short solve, and a certified optimum.
This chapter is a mathematical specification, not a Lean-certified solver. For comparison, rubik-lean4 at commit b8a5a09 formalizes the fixed-frame move and sticker correspondence, while rubiks-cube-group at commit 3baebd73 formalizes the legal-state subgroup; neither repository is used here as a formal proof of the search, diameter, or optimality claims above.
From move sequences to play [frap-0006]AGENTDRAFTED
From move sequences to play [frap-0006]AGENTDRAFTED
A formal move description becomes useful only when a player can apply it and reproduce its result. Play gives the mathematics an immediate test of intelligibility: a notation should identify a move unambiguously, a displayed turn should agree with the stated action, and replaying a sequence should reproduce the same state. Scrambling, undoing, recognizing a case, and following a solution all depend on those agreements.
A replay contract
A replay contract
Let \(S\) be a declared state space and let every legal move \(m\) be a reversible map \(S\to S\). A notation parser is correct only if it maps a token to one such map, with an inverse token satisfying
\[m^{-1}m=\operatorname {id}_S.\]For a word \(w=m_1m_2\cdots m_k\), we read moves from left to right as in the complete layer-first method:
\[s_0=s,\qquad s_i=m_i(s_{i-1}),\qquad \operatorname {replay}(w,s)=s_k.\]A replay test therefore records the initial state, the token list, the convention for viewing each face, and the final state. Replaying \(w\) followed by \(w^{-1}\) must return to \(s\); two displays are equivalent only after their resulting states, rather than their typography, agree.
Two traces that expose the conventions
Two traces that expose the conventions
The tetrahedron turn gives a short noncommuting trace. Starting at the recorded incidence position \((1,124)\), the \(H\)-move followed by the \(K\)-move reaches \((4,134)\). Reversing the order reaches \((3,234)\). The two words are therefore different maps, even though each move separately has order three. A player can check this by stepping through the two token lists and comparing the final records.
The cube face turn fixes the frame and turns only the chosen layer. The global shape map \(q(x,y,z)=(y,-x,z)\) sends the four \(z=1\) corners around a four-cycle; the local puzzle move restricts this map to that layer and fixes the opposite layer pointwise. This is a useful display test: a global rotation of the drawing is not the same operation as the local puzzle move, and the unturned center must not move merely because the picture was rotated.
From recognition to a solve
From recognition to a solve
A reproducible solve has five recorded stages: identify the state in the chosen coordinates; state the target condition; choose a move word; replay it from the recorded state; and check the target and preserved invariants. The layer-first method supplies a human version: each stage fixes information and uses a stabilizer for what remains. The computer account supplies a search version: a returned word is an upper bound, while a projected-distance table gives a lower bound.
These certificates should be reported separately. A valid replay shows that the word reaches the target. A short word improves an upper bound in the named metric. A shortest-path claim additionally needs an exhaustive search or a matching lower bound. The distinction also applies to a scramble: scrambling and spectra requires the move law and length before a distributional claim can be evaluated.
The worked replay and projected lower bound makes this separation concrete: one fixed-frame scramble is replayed by its inverse, a projected search supplies a lower bound, and the ten-token word supplies an upper bound. The example closes the replay loop while leaving the all-state method and any optimality claim at their stated scopes.
What a playing interface can check
What a playing interface can check
A small interface can make the contract visible without pretending to replace it. It can reject an unknown token, show the affected pieces, step through a word, undo by inverse tokens, and compare the final state with a target. It can also display parity, orientation, or subgroup coordinates as diagnostics, provided each coordinate is tied to the declared state model.
An animation illustrates a claim; the move map and replay log are the evidence for it. The interface should therefore expose the convention, the exact token sequence, and the before-and-after state so another person or program can reproduce the check. The existing Rubik's Cube resources collect notation, methods, and demonstrations; the companion FRAP repository can later host executable versions of these checks.
Further connections [frap-0007]AGENTDRAFTED
Further connections [frap-0007]AGENTDRAFTED
The total-orientation character can expose a constraint, but what survives when we change the local frame or the dimension? Framed orientations and transfer and dimension develop the first connections: wreath product records positions and local transport, while abelianized characters detect constraints when the allowed generators preserve them [marchetti2025rubik, Section 3.1]. Finite-index transfer organizes related calculations through coset representatives [mayer2015artin, Sections 3.1--3.3]. The dimension calculation explains how a local abelianization can lose this detecting power without deciding reachability.
The following outlooks ask different questions about transport and functions on a move group. Each needs its own construction; neither is a prerequisite for continuing to the layered cubes.
Label transport and topology [frap-0014]AGENTDRAFTED
Label transport and topology [frap-0014]AGENTDRAFTED
A sequence of puzzle moves may return pieces to their positions while changing their orientations. The first question is what local return map records that change; the cycle criterion computes it. A related question asks how labels move between neighboring simplices. The projectivity construction of Izmestiev and Joswig makes that question precise, and the complete unfolding records the topology of one such transport system [izmestiev2002branched, Sections 2.1--2.3.3].
Perspectivities along facet paths
Perspectivities along facet paths
Let \(K\) be a pure \(d\)-dimensional simplicial complex. If neighboring facets \(\sigma \) and \(\tau \) share a ridge, \(\sigma \) has one vertex \(v(\sigma ,\tau )\) not in \(\tau \). The perspectivity
\[h_{\sigma ,\tau }:V(\sigma )\longrightarrow V(\tau )\]swaps that exceptional vertex with \(v(\tau ,\sigma )\) and fixes the common ridge vertices. For a facet path \(\gamma =(\sigma _0,\ldots ,\sigma _n)\), its projectivity is the composite
\[\langle \gamma \rangle =h_{\sigma _0,\sigma _1}\cdots h_{\sigma _{n-1},\sigma _n}.\]A closed facet path based at \(\sigma _0\) gives a permutation of \(V(\sigma _0)\). The set of these permutations is the projectivity group \(\Pi (K,\sigma _0)\leq \operatorname {Sym}(V(\sigma _0))\); changing the base facet conjugates the group when the dual graph is connected. The inverse path supplies the inverse permutation, so this is transport with a genuine composition law [izmestiev2002branched, Section 2.1].
Coloring as a trivial-transport test
Coloring as a trivial-transport test
A proper coloring of the vertices of \(K\) with \(d+1\) colors gives every facet a consistently labeled vertex set. Each perspectivity preserves those labels, so every projectivity is the identity. Thus proper coloring is a sufficient condition for \(\Pi (K)=1\); a nontrivial projectivity group is an obstruction to such a global labeling [izmestiev2002branched, Section 2.1].
This is a useful comparison with a framed puzzle. A local frame assigns labels in one fiber, and a move transports them to another fiber. The framed transport and its total-orientation character measure the return action in the puzzle model. Projectivities do the analogous bookkeeping for simplex vertices, but the two constructions have different state spaces and move laws. No identification between their groups is being assumed.
Complete unfolding as a transport cover
Complete unfolding as a transport cover
Fix a base facet and a labeling of its vertices by \(0,\ldots ,d\). A facet reached by a path inherits a labeling by transporting along that path. Different paths can give different admissible labelings, precisely when their projectivity differs. The complete unfolding keeps these admissibly labeled facets as separate sheets and glues neighboring sheets only when their labels agree on the common ridge. It carries a canonical map back to \(K\); the base projectivity group acts by permuting these sheets. The complete unfolding itself has trivial projectivity group [izmestiev2002branched, Section 2.2, Proposition 2.2.2].
The construction is therefore a topological record of transport failure: a loop in the base may close geometrically while changing the sheet label. The complete unfolding removes that ambiguity by remembering the transported labeling. This is analogous to a covering-space monodromy calculation; the branch locus is additional local-combinatorial data of the unfolding and is not inferred here from the puzzle model.
The tetrahedral boundary example
The tetrahedral boundary example
For the boundary complex \(\partial \Delta ^3\), the projectivity group is \(S_3\). Its complete unfolding is glued from 24 triangles. Identifying opposite sides of the triangulated hexagon gives a torus \(T^2\); the canonical map to the tetrahedral boundary, topologically \(S^2\), is a six-fold branched covering. There are four branch points on \(S^2\); each has three preimages, each of branching index two [izmestiev2002branched, Section 2.3.3, Figure 3].
The example separates three pieces of data that are easy to conflate: the base triangulation, the permutation group generated by facet-path transport, and the topology of the unfolded surface. The torus is not a claim about a cube solver. It is a concrete model showing how local label transport can assemble a global branched cover.
A comparison between these constructions must name the fiber, the local transport map, and the allowed paths before relating topology to puzzle orientation. The projectivity example supplies one transport vocabulary; the framed cube account supplies a different finite-state calculation. A bridge between them would require an explicit map between those data and a proof that it preserves composition, return maps, and the claimed topology.
Scrambling, spectra and search coordinates [frap-0015]AGENTDRAFTED
Scrambling, spectra and search coordinates [frap-0015]AGENTDRAFTED
Random moves raise a different question from solving: when, and how quickly, does a scramble lose information about its starting state? A random walk depends on its allowed moves and their probabilities. We use the fixed-frame three-layer move group from the complete cube account, and write \(G\) for its reachable state group. A walk with step law \(\mu \) has distribution
\[\Pr [X_k=g]=\mu ^{*k}(g)\]from the solved state, where convolution records the successive moves.
A parity calculation before mixing claims
A parity calculation before mixing claims
Let \(\varepsilon :G\to \{+1,-1\}\) be the sign of the corner permutation. Each face quarter-turn or inverse is a four-cycle on corners, so \(\varepsilon =-1\); each face half-turn is a product of two transpositions, so \(\varepsilon =+1\). If the walk chooses uniformly from the twelve quarter-turns and inverse quarter-turns, then
\[\varepsilon (X_k)=(-1)^k\]with probability one. Its support is therefore contained in one parity coset at every fixed time, while the uniform distribution on \(G\) gives equal mass to the two cosets. The total-variation distance from uniform is at least \(1/2\) for every \(k\). This walk cannot converge to uniform: the obstruction is periodicity, not a slow estimate of a mixing time.
The usual eighteen-move HTM law gives a different exact observable. Six half-turns have sign \(+1\) and twelve quarter-turns or inverses have sign \(-1\), hence one step has
\[\mathbb E[\varepsilon (X_1)]=\frac 6{18}-\frac {12}{18}=-\frac 13.\]Independence gives \(\mathbb E[\varepsilon (X_k)]=(-1/3)^k\). Since uniform parity has expectation zero, the parity marginal alone gives the lower bound
\[\lVert \mathcal L(X_k)-\mathcal U_G\rVert _{\mathrm {TV}}\geq \frac 12\left (\frac 13\right )^k.\]This bound decays and does not prove convergence by itself. A lazy walk, which includes the identity with positive probability, removes this specific periodicity; a convergence statement still needs a generated reachable component and an aperiodicity argument.
Averaging and finite-group spectra
Averaging and finite-group spectra
For a function \(f:G\to \mathbb C\), the one-step averaging operator is
\[(T_\mu f)(g)=\sum _{s\in G}\mu (s)f(gs).\]Constants are fixed by \(T_\mu \). For a finite-dimensional unitary representation \(\rho \), its matrix coefficients
\[f_{u,v}(g)=\langle u,\rho (g)v\rangle \]form invariant blocks for this operator: averaging a coefficient replaces \(\rho (g)\) by multiplication by the Fourier block
\[\widehat \mu (\rho )=\sum _{s\in G}\mu (s)\rho (s).\]Thus the nonconstant spectrum describes which observables retain memory. If the step support generates the reachable group and every nontrivial block contracts on the relevant quotient, then these blocks decay and the walk converges to uniform on that component. The hypotheses matter: the quarter-turn walk above fails the aperiodicity test, so no spectral slogan can erase its parity obstruction.
The same calculation explains why a prescribed scramble length is not a universal guarantee of randomness. A distance bound answers how far a state can be from solved; a distributional claim asks how the whole law projects onto every persistent observable. These are different certificates.
Fourier coordinates for learned search
Fourier coordinates for learned search
Pan and Kondor use irreducible-representation matrix coefficients as a Fourier basis for learned value functions on permutation puzzles [pan2021fourier, Sections 4--4.1]. Their experiments compare learned scores that choose moves with conventional heuristic and value-based search; the paper explicitly discusses the distinction from an admissible lower bound [pan2021fourier, Section 6]. A learned score can rank promising moves while overestimating or underestimating the remaining distance. It is therefore evidence about search guidance, not a shortest-path certificate.
For the cube, a safe lower bound can still be obtained from the exact projected distances in a pattern database as in computer solving and efficiency. A Fourier score may be combined with that bound as a tie-breaker or move-ordering device, but replacing the bound with the score changes the guarantee. The representation coordinates explain how a search function is organized; they do not, without an error theorem, make it admissible.
The displayed parity bounds and finite-operator framework are the results established here. They do not claim a full-cube mixing time, a universal scramble length, or a reproduced machine-learning benchmark. Those would require a declared move law, reachable component, statistical or spectral analysis, and independently checked computational evidence.
Which moves survive a quotient? [frap-0019]AGENTDRAFTED
Which moves survive a quotient? [frap-0019]AGENTDRAFTED
A quotient of observations is useful only when the moves still have a well-defined action on the observations. Let \(X\) be a declared sticker state set, let \(G\) act on \(X\), and let the surjection \(q:X\twoheadrightarrow Y\) identify the observations we want to retain (equivalently, take \(Y=q(X)\)). The move \(g\in G\) preserves the fibers of \(q\) when
\[q(x)=q(x')\Longrightarrow q(gx)=q(gx')\qquad (x,x'\in X).\]Exactly in this case there is a unique induced map \(\bar g:Y\to Y\) with
\[q\circ g=\bar g\circ q.\]If \(g\) is a bijection and \(X\) is finite, then \(\bar g\) is surjective and therefore bijective. In an infinite setting, require the inverse move to preserve fibers as well. Thus, for the finite cube action below, the fiber-preserving bijections form a subgroup; a quotient does not automatically inherit the whole puzzle action.
The antipodal sticker quotient
The antipodal sticker quotient
For the ordinary cube, use the surface-cell and local frame convention in how the cube models connect and the complete three-layer cube. Represent a sticker in the sticker state by a pair \((p,n)\), where \(p\in \{-1,0,1\}^3\) satisfies \(\lVert p\rVert _\infty =1\) and \(n=\operatorname {sgn}(p_i)e_i\) for each nonzero coordinate \(p_i\). Thus corners, edges and face centers contribute \(8\cdot 3\), \(12\cdot 2\) and \(6\cdot 1\) pairs, respectively, for 54 stickers. The antipodal identification is the involution
\[a(p,n)=(-p,-n),\qquad q(p,n)=\{(p,n),a(p,n)\}.\]Its sticker fibres pair opposite stickers. This is a quotient of the sticker state action on labelled stickers; it is not the same as forgetting equal colors or quotienting by whole-cube rotations.
Why one face turn fails
Why one face turn fails
The positive-\(z\) face turn uses
\[u(x,y,z)=(y,-x,z)\]on every sticker whose cubie has \(z=1\), rotating both its position and its normal, and fixes the other cubies. Take a top sticker and its antipode, for example
\[x=((1,1,1),e_z),\qquad a(x)=((-1,-1,-1),-e_z).\]The turn sends \(x\) to the sticker at \(((1,-1,1),e_z)\), while it fixes \(a(x)\). These outputs are not an antipodal pair, so \(q(ux)\ne q(u\,a(x))\). The single \(U\) move therefore does not descend to the antipodal quotient.
A synchronized opposite-layer move
A synchronized opposite-layer move
The clockwise turn of the negative-\(z\) face, viewed from that face, is the inverse global rotation on \(z=-1\). Write it as \(d\); its inverse \(d^{-1}\) uses the same global rotation as \(u\). The composite \(u d^{-1}\) rotates both opposite layers by the same linear map and fixes the middle cubies. It commutes with the antipodal involution:
\[a\,(u d^{-1})=(u d^{-1})\,a.\]Consequently it preserves every antipodal fiber and induces a bijection on \(Y\). A direct check of all 54 stickers gives the same result: \(U\) fails on the displayed pair, while the synchronized \(U D'\) move maps every antipodal pair to an antipodal pair. The surviving action is therefore an action of the fiber-preserving subgroup, not of the six ordinary face turns individually.
What the cover does not provide
What the cover does not provide
A covering or quotient of the underlying shape supplies a map of shape data. It does not by itself supply a map between sticker-state spaces, a chosen fiber relation, or an equivariance proof for each legal move. Those data are separate: the explicit cube action records which stickers a face turn moves, while the quotient records which states are identified. A move descends only after the displayed fiber test has been checked.
This is the precise limit of the comparison with the complete unfolding in label transport and topology. Projectivity and branched unfolding describe transport of simplex labels; the antipodal example describes descent of a particular sticker action. They pose analogous questions about information lost by identification, but neither construction is being identified with the other. A general lifting or descent classification is outside this note.
The practical rule is short: state the state space, the quotient map and the move action before saying that a move survives identification. The antipodal calculation supplies both a negative and a positive finite example, while preserving the distinction between a shape cover and a compatible puzzle action.
How the cube models connect [frap-001A]AGENTDRAFTED
How the cube models connect [frap-001A]AGENTDRAFTED
An abstract cube turn records incidence positions and restricts a shape symmetry to one facet. A layered-cube turn records cubies, stickers, frames and allowed layers. For the ordinary three-layer cube these are two descriptions of the same action; the map below identifies their coordinates.
From facet incidence to the 54-sticker state
From facet incidence to the 54-sticker state
The facet calculation in one ordinary cube face turn selects the facet-colored part of the incidence set. Put the cube's surface cells at \(p\in \{-1,0,1\}^3\ \text {with}\ \lVert p\rVert _\infty =1\). A visible sticker is a pair \((p,n)\), where \(n=\operatorname {sgn}(p_i)e_i\) for each nonzero coordinate \(p_i\). Thus a corner has three visible normals, an edge has two, and a face center has one:
\[8\cdot 3+12\cdot 2+6=54.\]The vertex--facet incidences in the facet-colored set map to the pairs above by sending a cube vertex, edge, or facet to its surface-cell coordinate and its incident facet normal. Conversely, the zero-coordinate pattern of \(p\) determines the cubie (three nonzero entries for a corner, two for an edge, one for a centre), and \(n\) determines the incident facet, so this is a bijection between the 54 incidences and the 54 pairs. The cubie counts and this incidence decomposition follow the general model in [bonzio2018nxnxn, Sections 2--3]; the displayed pairing and 54-count are the calculation used here. For \(N=3\), group these pairs into eight corner and twelve edge sticker fibres, leaving the six center positions as fixed frame marks. A legal outer-face move preserves this partition and carries the labels in a corner fibre or edge fibre to the corresponding destination fibre. Write \(C_p=\{(p,\operatorname {sgn}(p_i)e_i):p_i\ne 0\}\) for a corner fibre and \(E_p\) for an edge fibre. For a corner, order its normals as \(L_p=(u_p,f_p,r_p)\), where \(u_p=\operatorname {sgn}(p_3)e_3\), \(f_p=\operatorname {sgn}(p_2)e_2\), and \(r_p=\operatorname {sgn}(p_1)e_1\). For an edge, put first the U/D normal when \(p_3\ne 0\), otherwise the F/B normal, and put the other normal second. A move sends \(C_p\) or \(E_p\) to a destination fibre. Let \(k_p\in \{0,1,2\}\) be the index of the transported U/D normal in \(L_{p'}\). If the source cubie has \(p_3=+1\), set \(x_p=k_p\); if it has \(p_3=-1\), set \(x_p=-k_p\) in \(\mathbb Z_3\). Thus each side turn gives two \(+1\) and two \(-1\) corner twists, while U/D turns give zero, matching the U/D-sticker convention in the complete three-layer cube. For an edge, its distinguished normal agrees or disagrees with the first destination label, giving \(z\in \mathbb Z_2\). This explicit extraction fixes each per-fibre bijection and the destination permutation without asserting an unstated cyclic convention. Therefore it induces exactly the fixed-frame coordinates
\[(\sigma ,x;\tau ,z)\in S_8\times (\mathbb Z_3)^8 \times S_{12}\times (\mathbb Z_2)^{12}\]used in the complete three-layer cube. More explicitly, if a move sends a corner fibre \(C_p\) to \(C_{p'}\), set \(\sigma (p)=p'\); the destination edge fibre similarly gives \(\tau \). For the positive-\(z\) turn \(q(x,y,z)=(y,-x,z)\) from one ordinary cube face turn,
\[((1,1,1),e_z)\longmapsto ((1,-1,1),e_z),\qquad ((1,1,1),e_y)\longmapsto ((1,-1,1),e_x).\]This exhibits both the destination corner and the transported local frame. The induced map is a change of state description for the legal action: it sends a sticker permutation to its corner and edge destination permutations together with the local frame changes. It does not assert that every permutation of the 54 positions is a legal cube move.
This also separates two kinds of forgetting. Passing from the incidence action to the displayed coordinates forgets the individual sticker addresses inside each recorded local frame. Passing from labelled cubies to an ordinary colour observation forgets equal-looking labels. The latter is the observation quotient discussed in which moves survive a quotient, and it is a separate identification of states rather than a change in these coordinates.
What changes when layers are added
What changes when layers are added
For larger \(N\), the same surface-cell description retains the corner and edge fibers but adds coupled-edge and center orbits. Inner layers move those new fibers, and even and odd sizes have different orbit signatures. The all-\(N\) coordinates in the layered-cube law therefore extend the three-layer state description rather than replace it. Their parity and orientation equations are stated for a labelled fixed-frame model; they are not obtained by treating every center sticker as one of the twelve ordinary edges.
The transition is consequently a specialization in one direction: the \(N=3\) outer-layer case of the family of layered cubes gives the ordinary fixed-frame action, while the abstract facet action explains why that outer turn moves precisely the selected surface fibers. Whole-cube rotations, marked centers, central slices and colour-only identifications are additional choices, not silent changes of coordinates.
What the identification supports
What the identification supports
The explicit identification supports this chain of state descriptions:
- incidence, flags and a local facet action explain what a move is;
- the layered model and its first law explain which fibres and constraints appear as \(N\) changes;
- the fixed-frame three-layer coordinates make the three familiar constraints and their constructive sufficiency explicit;
- human methods and computer searches use the same state action while assigning different meanings to preservation, cost and optimality;
- a declared move word can be replayed and checked against these state descriptions.
Three linked comparisons use the same distinctions. Label transport and branched unfolding study return maps on simplex labels; compatible quotients test whether an identification of sticker observations inherits a move; and scrambling and spectra study which functions retain memory under a declared move law. These are comparisons of transport, forgetting and randomization, not identifications with the fixed-frame cube action.
Label transport and topology [frap-0014]AGENTDRAFTED
Label transport and topology [frap-0014]AGENTDRAFTED
A sequence of puzzle moves may return pieces to their positions while changing their orientations. The first question is what local return map records that change; the cycle criterion computes it. A related question asks how labels move between neighboring simplices. The projectivity construction of Izmestiev and Joswig makes that question precise, and the complete unfolding records the topology of one such transport system [izmestiev2002branched, Sections 2.1--2.3.3].
Perspectivities along facet paths
Perspectivities along facet paths
Let \(K\) be a pure \(d\)-dimensional simplicial complex. If neighboring facets \(\sigma \) and \(\tau \) share a ridge, \(\sigma \) has one vertex \(v(\sigma ,\tau )\) not in \(\tau \). The perspectivity
\[h_{\sigma ,\tau }:V(\sigma )\longrightarrow V(\tau )\]swaps that exceptional vertex with \(v(\tau ,\sigma )\) and fixes the common ridge vertices. For a facet path \(\gamma =(\sigma _0,\ldots ,\sigma _n)\), its projectivity is the composite
\[\langle \gamma \rangle =h_{\sigma _0,\sigma _1}\cdots h_{\sigma _{n-1},\sigma _n}.\]A closed facet path based at \(\sigma _0\) gives a permutation of \(V(\sigma _0)\). The set of these permutations is the projectivity group \(\Pi (K,\sigma _0)\leq \operatorname {Sym}(V(\sigma _0))\); changing the base facet conjugates the group when the dual graph is connected. The inverse path supplies the inverse permutation, so this is transport with a genuine composition law [izmestiev2002branched, Section 2.1].
Coloring as a trivial-transport test
Coloring as a trivial-transport test
A proper coloring of the vertices of \(K\) with \(d+1\) colors gives every facet a consistently labeled vertex set. Each perspectivity preserves those labels, so every projectivity is the identity. Thus proper coloring is a sufficient condition for \(\Pi (K)=1\); a nontrivial projectivity group is an obstruction to such a global labeling [izmestiev2002branched, Section 2.1].
This is a useful comparison with a framed puzzle. A local frame assigns labels in one fiber, and a move transports them to another fiber. The framed transport and its total-orientation character measure the return action in the puzzle model. Projectivities do the analogous bookkeeping for simplex vertices, but the two constructions have different state spaces and move laws. No identification between their groups is being assumed.
Complete unfolding as a transport cover
Complete unfolding as a transport cover
Fix a base facet and a labeling of its vertices by \(0,\ldots ,d\). A facet reached by a path inherits a labeling by transporting along that path. Different paths can give different admissible labelings, precisely when their projectivity differs. The complete unfolding keeps these admissibly labeled facets as separate sheets and glues neighboring sheets only when their labels agree on the common ridge. It carries a canonical map back to \(K\); the base projectivity group acts by permuting these sheets. The complete unfolding itself has trivial projectivity group [izmestiev2002branched, Section 2.2, Proposition 2.2.2].
The construction is therefore a topological record of transport failure: a loop in the base may close geometrically while changing the sheet label. The complete unfolding removes that ambiguity by remembering the transported labeling. This is analogous to a covering-space monodromy calculation; the branch locus is additional local-combinatorial data of the unfolding and is not inferred here from the puzzle model.
The tetrahedral boundary example
The tetrahedral boundary example
For the boundary complex \(\partial \Delta ^3\), the projectivity group is \(S_3\). Its complete unfolding is glued from 24 triangles. Identifying opposite sides of the triangulated hexagon gives a torus \(T^2\); the canonical map to the tetrahedral boundary, topologically \(S^2\), is a six-fold branched covering. There are four branch points on \(S^2\); each has three preimages, each of branching index two [izmestiev2002branched, Section 2.3.3, Figure 3].
The example separates three pieces of data that are easy to conflate: the base triangulation, the permutation group generated by facet-path transport, and the topology of the unfolded surface. The torus is not a claim about a cube solver. It is a concrete model showing how local label transport can assemble a global branched cover.
A comparison between these constructions must name the fiber, the local transport map, and the allowed paths before relating topology to puzzle orientation. The projectivity example supplies one transport vocabulary; the framed cube account supplies a different finite-state calculation. A bridge between them would require an explicit map between those data and a proof that it preserves composition, return maps, and the claimed topology.
Math notes (agent drafts) [uts-016Q]
Math notes (agent drafts) [uts-016Q]
Notes on formulating discrete-induced physics [fdip-0001]
📄PDFAGENTDRAFTED
- November 3, 2026
- Utensil Song
Notes on formulating discrete-induced physics [fdip-0001]
📄PDFAGENTDRAFTED
- November 3, 2026
- Utensil Song
Physics often models length, time and field values as continuous (infinitely divisible) quantities. Measurements have finite resolution, so they do not establish that this continuum is fundamental. The real numbers are its usual mathematical form. The hypothesis is that geometry, time and matter can be induced from finite carriers and exact algebra, with continuum physics recovered at large scales. A classical field assigns values to points of space; in this discrete setting, the points are vertices or edges of a finite graph. Finitely many coordinates need not mean finitely many possible values: later Gaussian probability laws are laws on a real inner-product space. What a structure induces is kept separate from what must be supplied. A finite incidence presentation records the finite vertex set, edge set and endpoint maps; the alternating four-cycle of Example [fdip-0003] makes the additional weights explicit. Reordering vertices changes a representation; changing weights changes the model. Gaussian elimination in Elimination and retained observables uses a specified quadratic action and reference measure.
Induced geometry provides one motivation. On a fixed background, one-loop matter fluctuations generate an Einstein-Hilbert term in the effective action [visser2002sakharov, Section 1, Eq. (1)], so the gravitational action need not be assumed: it can be induced by the matter content. Keeping supplied microscopic data, state assumptions and induced structure apart is then a distinction with content. Conjecture [fdip-003X] asks for an arithmetic scheme with a Clifford sheaf and a finite-group action, for a map from a moduli stack controlling the continuum limit and the background dependence, and for quantum-field-theory parameters given by special L-values. Spacetime, physical parameters, the Standard Model equations and gravitational equations stay outside those finite constructions. Discrete induction and its open interfaces records the comparisons that remain open: the physical environment map, and the continuum question, which is asked and not answered. The groupoid and the realization do not supply a site, a stack, or a descent. No moduli map is constructed.
These notes develop finite constructions and do not propose a physical theory. The parts run from fields on finite carriers through Gaussian laws, symmetry and Clifford algebras, to arithmetic families and a fixed-mode comparison on a supplied circle. Geometric realization then asks which information survives when weights are forgotten. Selected backgrounds, gauge fields, Euclidean time and lattice fermions give the finite constructions that the structure chapters and the closing § [fdip-003W] compare. Remark [fdip-004E] maps the parts. The alternating four-cycle returns as the example that ties a later construction to specified fields, weights and observables.
Remark. How to read these notes [fdip-004E]AGENTDRAFTED
- November 3, 2026
Remark. How to read these notes [fdip-004E]AGENTDRAFTED
- November 3, 2026
The reading route has 14 parts. The diagrams show selected prerequisites for reading, not every premise of every result. An arrow means that its destination uses a construction or comparison from its source. Each statement still gives its precise hypotheses. Questions on the arrows motivate the next topic; they do not assert that the notes already derive the corresponding physics.
The overview includes the full intended route. The prime-by-prime Gaussian extension, Structure and the concluding comparison of fixed and free data are published. The Grassmann integration chapter, fermionic elimination, covariant Dirac operators and the Wilson term develop the fermion part. The compatibility test fixes one finite spinor datum. The larger proposals remain open tests. A solid arrow into open material records an intended prerequisite, not a result already proved. In the part diagrams, a dotted box names a neighboring part; every arrow is solid.
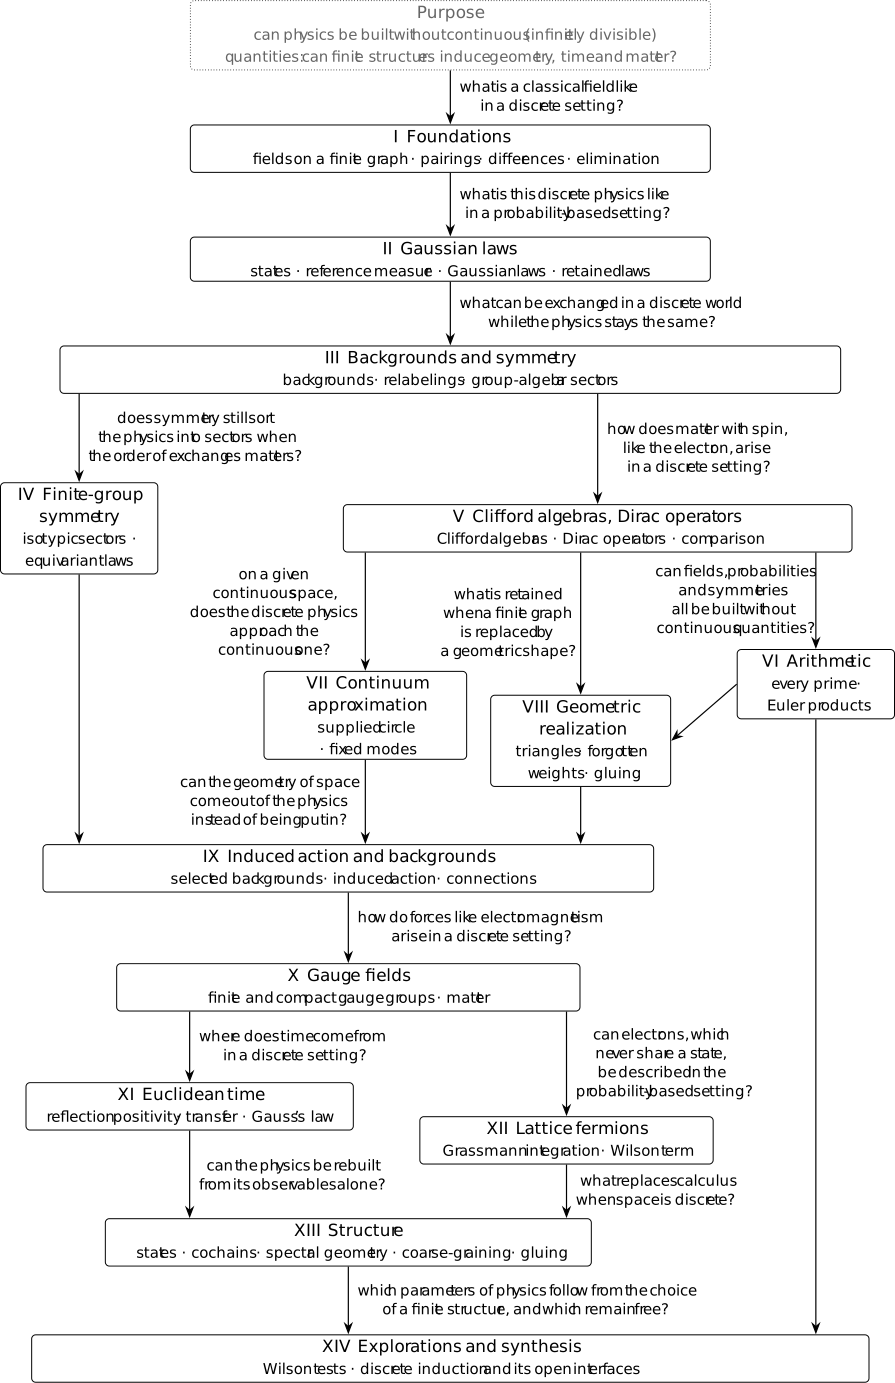
After backgrounds and symmetry, the route separates finite-group sectors from Clifford algebras and spatial Dirac operators. The latter lead to arithmetic, approximation on a supplied circle and geometric realization. These are not three independent branches: the fiber-constancy criterion remains in Arithmetic and is used by Realization. The direct comparison from Part V also remains visible. The figures therefore show selected prerequisites, not an exact transitive reduction of all dependencies.
Finite-group sectors, circle approximation and realization meet in the study of selected backgrounds and induced actions. Connections lead to gauge fields; Euclidean time and the fermion branch then feed the Structure part. The fermion branch currently supplies its Grassmann integration, elimination, covariant Dirac operators and the free Wilson remedy. The arrow from gauge fields to Euclidean time meets the gauge transfer and Gauss's law. Reflection positivity alone does not supply that shift. The arrow from gauge fields to lattice fermions meets the covariant Dirac operator and the free Wilson remedy above, not Grassmann integration or fermionic elimination, and it does not identify those operators with a physical electron. Arithmetic and Structure contribute different questions to the closing explorations. These destinations are earned by specific finite constructions, rather than adopted as starting axioms.
- Part I, Foundations: fields on finite carriers, reference pairings, differences and algebraic elimination.
- Part II, Gaussian laws: states, reference measure, positive and constrained Gaussian laws, and retained observables.
- Part III, Backgrounds and symmetry: transported data, observables and half-turn sectors.
- Part IV, Finite-group symmetry: real isotypic projectors, multiplicities and Gaussian sector laws.
- Part V, Clifford algebras, spatial Dirac operators and enriched comparison: distinct questions about quadratic forms, first-order operators and preserved observables.
- Part VI, Arithmetic families, followed by the Gaussian extension at every prime.
- Part VII, Continuum approximation: a supplied circle and fixed Fourier modes, not a general emergent continuum.
- Part VIII, Geometric realization: which information survives a replacement by a shape, including the weights it can forget.
- Part IX, Selected backgrounds, induced actions and interactions, local laws and gluing, and connections and holonomy.
- Part X, Gauge fields: finite surface laws, matter-induced actions, dynamical connections and compact groups.
- Part XI, Euclidean time: reflected pairings, explicit transfer operators and Gauss's law. Reflection positivity alone does not supply a time shift.
- Part XII, Lattice fermions: finite Grassmann integration, determinants, Pfaffians, Wick identities and elimination, followed by covariant Dirac operators and doubling and the Wilson remedy.
- Part XIII, Structure: operator-algebra, cochain, spectral-geometry, coarse-graining and gluing questions, developed in the chapters of that part. Speculative and optional sections retain those qualifications.
- Part XIV, Explorations and synthesis: the existing conjecture and finite interfaces, the compatibility test, and a comparison of what is fixed or free. The larger proposals remain open tests. The synthesis records the remaining open comparisons: the physical environment map, the continuum question, asked and not answered, with no moduli map claimed, and geometric or moduli structure beyond the published groupoid and realization.
The part diagrams appear at their openings. The Structure diagram routes its time input to the transfer chapter and its fermion input to the Dirac-Kähler chapter, where those suppliers are actually intended. It does not make the earlier states or cochains definitions consequences of time evolution or fermions. The root retains one linear reading order; forward examples and open questions orient that reading without becoming premises of the preceding proofs.
Finite fields and operator products [fdip-0015]AGENTDRAFTED
- October 20, 2026
Finite fields and operator products [fdip-0015]AGENTDRAFTED
- October 20, 2026
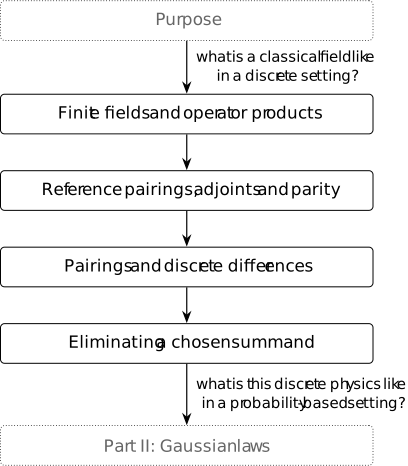
The coefficient ring is commutative and unital; the operator product need not commute. Positive counting pairings and weights enter in the real specialization. Working over a ring first separates identities of incidence, composition and elimination from positivity and integration. The general adjoint construction assumes perfect pairings, and elimination requires an invertible eliminated block; these hypotheses do not follow from the coefficient ring alone. Real positivity and measure are additional data for the later Gaussian laws.
A measurement has finite resolution, and a lattice regularisation keeps finitely many sites. Both give finite data, while the field equations are written for a continuum. Can the continuum be induced from finite data? An answer must begin with a field on finitely many points: a value at each point, or along each step between them.
Discussion. The field equations in three languages [fdip-00AA]AGENTDRAFTED
- November 4, 2026
Discussion. The field equations in three languages [fdip-00AA]AGENTDRAFTED
- November 4, 2026
In the undergraduate course on electromagnetism the field equations arrive in the language of vector calculus. With a charge density \(\rho \) and a current \(J\), and with the constants set to one, they read \[\operatorname {div} E=\rho ,\qquad \operatorname {div} B=0,\qquad \operatorname {curl} E=-\partial _t B,\qquad \operatorname {curl} B=\partial _t E+J.\] 4 equations, two vector fields, and a potential \(A\) that enters when one wants to solve them. There the potential is primitive and the fields are derived from it by a gradient, and the metric sits in the operators: the divergence, the curl and the cross product all know about lengths and angles. Every object is continuous as well: \(\rho \) is a density, and \(\partial _t\) presupposes a parameter along which to differentiate.
A course in mathematical physics rewrites the system in the language of differential forms. The potential becomes a \(1\)-form \(A\) and the field strength its exterior derivative \(F=dA\). The exterior derivative needs no metric, so \(dF=0\) is a consequence of \(d\circ d=0\) rather than an equation to impose, and gauge transformations \(A\mapsto A+d\chi \) leave \(F\) unchanged by construction, which is why gauge theory is written this way. The metric reappears in the Hodge star that the equations with sources require, \(d\star F=\star j\), while \(d\) raises the degree of a form. [hassani2013mathematical, Section 28.5] writes the field equations this way.
Readers who have met geometric calculus will recognize the same system in the unified language that Hestenes and Sobczyk proposed for mathematics and physics. The electric and magnetic fields are then grades of one object, the bivector \(F=E+IB\), where \(I\) is the pseudoscalar of the algebra, the product of the 4 frame vectors, with \(I^2=-1\), so the magnetic field enters as the dual bivector \(IB\), and the pair forms one bivector rather than the vector and pseudovector of vector calculus. The derivative is the vector derivative \(\nabla \): the derivative along each direction of a chosen frame, combined into a single vector-valued operator by the geometric product with the frame vectors. It acts by geometric multiplication, and a vector multiplied that way by a multivector splits into two parts, \[\nabla F=\nabla \cdot F+\nabla \wedge F,\] an inner product giving a divergence and an outer product giving a curl. With it the 4 equations become \(\nabla F=J\), the divergence part carrying the sources and the curl part vanishing, so each original equation returns as a definite grade. Hestenes and Sobczyk develop the calculus [hestenes2012clifford], Doran and Lasenby carry it through classical electrodynamics [doran2003geometric, Section 7.1], and Macdonald's textbook is the treatment [macdonald2012vector]. Here one algebra and one derivative serve both objects, and the metric is neither an operator nor a dual: it is inside the geometric product, which is why the language carries a chosen spacetime with it.
All three ways of writing these equations need a limit: in each, a derivative compares values at points whose separation shrinks. Those points are not bare: the continuum carries a metric, a topology and a smooth structure, and that is what gives a separation, a direction and a gradient their meaning. On a lattice only finitely many points remain, and a direction becomes a step from one site to a neighbour. What is left of the gradient is the difference of the values at the two ends of each step. A derivative of a product obeys the Leibniz rule; does a difference of values obey it as well, or does something else take its place? And which changes of the potential does a difference fail to see?
A field assigns a coefficient to each vertex or edge. Along an oriented edge, the incidence map subtracts the source value from the head value. Endpoint pullbacks express this comparison between distinct field spaces. Composition supplies an operator product on a common field module; comparing it with pointwise field multiplication gives a discrete product rule. Lemma [fdip-0009] states that rule, and Example [fdip-00AP] shows where operator commutativity fails. The alternating four-cycle of Example [fdip-0003] supplies the weights and the half-turn that the examples below use.
Definition. Ring-valued incidence fields [fdip-0010]AGENTDRAFTED
- October 20, 2026
Definition. Ring-valued incidence fields [fdip-0010]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative ring with identity. Choose finite sets \(V,E\) and maps \(s,h:E\to V\). The edge \(e\) goes from \(s(e)\) to \(h(e)\); loops and distinct edges with the same endpoints are allowed. Call the finite sets together with their endpoint maps the carrier. The field modules are the vertex-field module and the edge-field module \[\mathcal F_R(V)=\{f:V\to R\},\qquad \mathcal F_R(E)=\{a:E\to R\}.\] Addition, scalar multiplication and multiplication are pointwise: \[(f+g)(v)=f(v)+g(v),\quad (rf)(v)=rf(v),\quad (fg)(v)=f(v)g(v).\] These are modules and commutative unital \(R\)-algebras; the unit is the constant field \(1\).
The zero ring and an empty vertex set or edge set are allowed. On an empty set there is one field, and the constant \(1\) is also zero. No nontriviality, pairing, retained subset or positivity is assumed. The algebra convention is [stacks2017stacks, Section 22.2], Tag 09JF. The module and algebra laws are in Lemma [fdip-00AC].
The alternating four-cycle of Example [fdip-0003] is an instance of these fields.
Definition. Pullbacks and the incidence map [fdip-00AQ]AGENTDRAFTED
- November 4, 2026
Definition. Pullbacks and the incidence map [fdip-00AQ]AGENTDRAFTED
- November 4, 2026
Let \(R\) be a commutative ring with identity, with the carrier of finite sets \(V,E\) and maps \(s,h:E\to V\), and the field modules over it. For a map \(a:E\to V\), its field pullback is \[a^*:\mathcal F_R(V)\to \mathcal F_R(E),\qquad (a^*f)(e)=f(a(e)).\] It preserves addition, scalars, products and the unit. The ring-valued incidence map is the typed difference \[d=h^*-s^*:\mathcal F_R(V)\longrightarrow \mathcal F_R(E).\] Thus \((df)(e)=f(h(e))-f(s(e))\). This is an \(R\)-linear map, with both coefficient rings equal to \(R\) and scalar homomorphism \(\sigma =\operatorname {id}_R\), as in Remark [ca-001G]. The two field modules need not coincide, so \(d^2\) has no meaning without an additional composable map. The pullback law, the linearity and the kernel of \(d\) are in Lemma [fdip-00AC].
For real oriented-graph incidence, see [spielman2009effective, Section 2.1, p. 4]; the ring-level claims follow from Lemma [fdip-00AC].
Remark. Incidence and the exterior derivative [fdip-00AB]AGENTDRAFTED
- November 4, 2026
Remark. Incidence and the exterior derivative [fdip-00AB]AGENTDRAFTED
- November 4, 2026
The potential of the preceding discussion is a field on the vertices: one value per site, added and scaled pointwise as in the vertex-field module. Along an edge the difference between the two endpoint values is what the edge carries, so the ring-valued incidence map takes a potential to the field strength read off the edges. On a cubic lattice whose steps are \(x\to x+\mu \), that difference is \(\varphi (x+\mu )-\varphi (x)\).
In the forms notation the potential is a \(0\)-form and the field strength a \(1\)-form, related by \(d\). The incidence map plays the role of \(d\) on \(0\)-forms, and it is not \(d\): the exterior derivative raises the degree of a form, while the incidence map runs from vertex fields to edge fields of one particular graph. A field pullback is composition with a map of the two finite sets, as in the substitution \(f'(x)=f(h(x))\).
Lemma. Basic properties of incidence fields [fdip-00AC]AGENTDRAFTED
- November 3, 2026
Lemma. Basic properties of incidence fields [fdip-00AC]AGENTDRAFTED
- November 3, 2026
Let \(R\) be a commutative unital ring, and let \(V,E,s,h\) and the field modules, field pullback and ring-valued incidence map be as in the two definitions above. The pointwise operations make both modules commutative unital \(R\)-algebras, the indicator fields are a basis of each, every field pullback preserves the operations, and \(d\) is \(R\)-linear. Call two vertices equivalent when they are equal or a finite sequence of edges has them as successive ends, ignoring orientation. The equivalence classes are the undirected components; a vertex that lies on no edge is a component of its own. Then \(df=0\) if and only if \(f\) is constant on each undirected component.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Every module and algebra identity follows by evaluation from the corresponding identity in \(R\). For each \(v\in V\), let \(\delta _v(u)\) be \(1\) if \(u=v\) and \(0\) otherwise. Evaluation at \(u\) proves \[f=\sum _{v\in V}f(v)\delta _v,\] and proves uniqueness of the coefficients. The same argument applies to edge fields. On an empty carrier the sum is empty and there is one field. Evaluation also proves every pullback law; for instance \(a^*(fg)(e)=f(a(e))g(a(e))\). Finally \[d(rf+g)(e)=r\bigl (f(h(e))-f(s(e))\bigr )+g(h(e))-g(s(e)),\] which proves linearity. These evaluations apply to the zero ring.
If \(df=0\), then \(f(h(e))=f(s(e))\) for every edge, so \(f\) takes the same value at the successive ends of any finite sequence of edges and is constant on each component. Conversely, the two ends of an edge lie in one component, and the two ends of a loop are the same vertex, so a field constant on each component has \(df=0\). The argument uses no division.
Remark. Gauge freedom of a potential [fdip-00AD]AGENTDRAFTED
- November 3, 2026
Remark. Gauge freedom of a potential [fdip-00AD]AGENTDRAFTED
- November 3, 2026
The kernel in Lemma [fdip-00AC] is the gauge freedom of the potential. Adding a constant on one undirected component leaves every edge difference unchanged, and the electric field is the negative of that difference. A vector potential is assigned to the edges, as the link variables of lattice gauge theory are, and its field strength is the difference of those values around a face. The identity \(d\circ d=0\) needs that second difference, from edge fields to face fields. The maps defined here run only from vertices to edges.
Definition. The incidence matrix [fdip-00AF]AGENTDRAFTED
- November 3, 2026
Definition. The incidence matrix [fdip-00AF]AGENTDRAFTED
- November 3, 2026
Let \(R\) be a commutative unital ring, and let \(d\) be the ring-valued incidence map of a finite carrier \(\,(V,E,s,h)\). Choose orders of the vertex and edge indicators. Let \(c_V:\mathcal F_R(V)\to R^{|V|}\) and \(c_E:\mathcal F_R(E)\to R^{|E|}\) send a field to its ordered values. The indicator expansion in Lemma [fdip-00AC] gives their inverses, where \(\delta _v\) is the indicator field of a vertex \(v\). The incidence matrix represents \(c_Edc_V^{-1}\): \[B_{ev}=(d\delta _v)(e)=\mathbf 1_{v=h(e)}-\mathbf 1_{v=s(e)}.\] Rows are indexed by edges and columns by vertices. A loop has a zero row; reversing an edge negates its row. This extends the oriented-graph sign convention of [spielman2009effective, Section 2.1, p. 4]. If coordinate reorderings are \(P_V,P_E\), then \(B'=P_EBP_V^{-1}\), since both sides send \(c'_V(f)\) to \(c'_E(df)\).
Example. The alternating four-cycle [fdip-0003]AGENTDRAFTED
- October 16, 2026
Example. The alternating four-cycle [fdip-0003]AGENTDRAFTED
- October 16, 2026
Let \(V=\mathbb Z/4\mathbb Z\) and \(E=\{e_0,e_1,e_2,e_3\}\), with \(s(e_i)=i\) and \(h(e_i)=i+1\) modulo \(4\). For \(t>0\), assign weights \[w_t(e_0)=w_t(e_2)=1,\qquad w_t(e_1)=w_t(e_3)=t.\] This is a weighted finite incidence presentation: the parameter \(t\) is supplied, and every edge weight is positive.
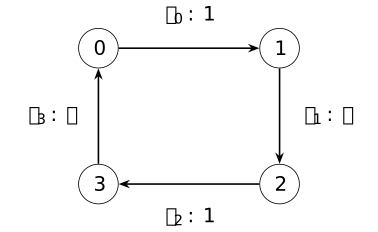
Each arrow points from source to head; the label gives its edge name and weight. A half-turn exchanges opposite vertices and edges.
On the real four-cycle, order vertices as \(0,1,2,3\) and edges as \(e_0,e_1,e_2,e_3\). The incidence matrix \(B\) of \(D\), and the coordinate array \(W_t\) of the weights, are \[B=\begin {pmatrix} -1&1&0&0\\ 0&-1&1&0\\ 0&0&-1&1\\ 1&0&0&-1 \end {pmatrix},\qquad W_t=\operatorname {diag}(1,t,1,t).\] Thus a field with ordered values \((a,b,c,d)\) has edge differences \((b-a,c-b,d-c,a-d)\). For \(f=\delta _1\), the edge values of \(Df\) are \((1,-1,0,0)\): the field rises along \(e_0\) and falls along \(e_1\).
The quadratic action of Example [fdip-002P] uses these same edge orientations and weights, with a positive mass term.
Define the half-turn on both sets by \[r_V(i)=i+2,\qquad r_E(e_i)=e_{i+2}.\] Applying either map twice adds 4, so both are involutions, and \(r_V(0)=2\) shows that the map on vertices is not the identity. Moreover, \[s(r_E(e_i))=i+2=r_V(s(e_i)),\] \[h(r_E(e_i))=i+3=r_V(h(e_i)).\] The half-turn therefore preserves the directed incidence data. Since \(i\) and \(i+2\) have the same parity, it also preserves the weights: \(w_t(r_E(e_i))=w_t(e_i)\). In contrast, a one-step rotation sends \(e_0\) to \(e_1\) and fails to preserve weights when \(t\ne 1\).
After forgetting orientations and weights, the underlying graph is
Mathlib's SimpleGraph.cycleGraph at 4 vertices, identifying
\(\operatorname {Fin}(4)\) with the residue classes modulo \(4\). That
declaration specifies the unweighted graph. The displayed matrix and
weight-preserving half-turn follow from the substitutions above.
Remark. Divergence and the discrete Poisson equation [fdip-00AG]AGENTDRAFTED
- November 3, 2026
Remark. Divergence and the discrete Poisson equation [fdip-00AG]AGENTDRAFTED
- November 3, 2026
The incidence matrix \(B\) is the difference matrix of the preceding discussion, and \(L=B^{\mathsf T}B\) is the graph Laplacian. The matrix \(-B^{\mathsf T}\) is the discrete divergence. With the edge field \(E=-B\varphi \), Gauss's law \(\nabla \cdot E=\rho \) becomes \[\,(-B^{\mathsf T})(-B\varphi )=B^{\mathsf T}B\varphi =L\varphi =\rho ,\] the discrete Poisson equation. Computations, and the later Laplacian chapters, use \(d\) in this matrix form.
Discussion. Products and derivatives [fdip-00AH]AGENTDRAFTED
- November 4, 2026
Discussion. Products and derivatives [fdip-00AH]AGENTDRAFTED
- November 4, 2026
A coupling that varies from site to site enters a lattice action as a coefficient: the term \(m\sum _v\varphi (v)^2\) for a constant mass \(m\) becomes \(\sum _v m(v)\varphi (v)^2\), so a fixed field multiplies the field at each site. Multiplying by a fixed field and taking differences along the edges are then two linear maps of one module, and composing them in the two orders gives two different maps. What is the map that multiplies, and how badly does it fail to commute with a difference?
Definition. Multiplication operators [fdip-00AI]AGENTDRAFTED
- November 3, 2026
Definition. Multiplication operators [fdip-00AI]AGENTDRAFTED
- November 3, 2026
Let \(R\) be a commutative unital ring and \(V\) a finite set. On the vertex-field module, each \(f\in \mathcal F_R(V)\) determines a multiplication operator \[M_f:\mathcal F_R(V)\to \mathcal F_R(V),\qquad M_f(g)=fg.\] The assignment \(f\mapsto M_f\) is an injective \(R\)-algebra map, \[M_{f+g}=M_f+M_g,\quad M_{rf}=rM_f,\quad M_{fg}=M_fM_g,\quad M_1=I.\] Proposition [fdip-0011] proves these identities from the ring laws.
Remark. The potential term [fdip-00AJ]AGENTDRAFTED
- November 3, 2026
Remark. The potential term [fdip-00AJ]AGENTDRAFTED
- November 3, 2026
The multiplication operator \(M_V\) is the potential term of a lattice Schrödinger operator, added to a difference operator. The assignment \(f\mapsto M_f\) is how a field acts on its own module, and \(M_f M_g=M_g M_f\). A shift need not commute with \(M_f\). That product is the operator product of Proposition [fdip-0011], and Example [fdip-00AP] computes the failure on a cycle.
Proposition. Composition and field multiplication [fdip-0011]AGENTDRAFTED
- October 20, 2026
Proposition. Composition and field multiplication [fdip-0011]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring. For \(R\)-modules \(M,N,P\), use \(\operatorname {Hom}_R(M,N)\) for additive, scalar-preserving maps. Thus linearity fixes \(\sigma =\operatorname {id}_R\). Given \(A\in \operatorname {Hom}_R(M,N)\) and \(B\in \operatorname {Hom}_R(N,P)\), write \[BA=B\circ A:M\to P.\] Composition is associative and \(R\)-bilinear where the types match. In particular, the endomorphisms \(\operatorname {End}_R(M)=\operatorname {Hom}_R(M,M)\) form an associative unital \(R\)-algebra, with unit \(I_M\) and central scalar map \(r\mapsto rI_M\).
On the vertex-field module, pointwise products are the multiplication operators. The map \(f\mapsto M_f\) is an injective \(R\)-algebra homomorphism into \(\operatorname {End}_R(\mathcal F_R(V))\). The proof evaluates those algebra laws. Example [fdip-00AP] exhibits endomorphisms that do not commute.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Pointwise addition and scalar multiplication make \(\operatorname {Hom}_R(M,N)\) a module: the linearity equations are preserved by both operations. If \(A,B\) are composable, then \(BA(rx+y)=B(rAx+Ay)=rBAx+BAy\), so \(BA\) is linear. For a third composable map \(C\), \((CB)A(x)=C(B(Ax))=C(BA)(x)\). The identity map is a two-sided unit. For composable maps with common source and target, \[\begin {aligned} B(A+A')(x)&=B(Ax)+B(A'x),\\ (B+B')A(x)&=B(Ax)+B'(Ax),\\ B(rA)(x)&=rB(Ax),\qquad (rB)A(x)=rB(Ax). \end {aligned}\] These prove distributivity and bilinearity. For an endomorphism \(A\), \((rI)A(x)=rAx=A(rx)=A(rI)(x)\), proving centrality of the scalar map; its unit, addition and product laws follow immediately by evaluation.
Pointwise multiplication makes \(M_f\) linear. Evaluating the 4 identities \[M_{f+g}=M_f+M_g,\quad M_{rf}=rM_f,\quad M_{fg}=M_fM_g,\quad M_1=I\] on a field proves them using the ring laws. If \(M_f=M_g\), applying both maps to the constant field \(1\) yields \(f=g\); this also holds when \(V\) is empty or \(R\) is the zero ring.
The Hom-module and algebra conventions are
[stacks2017stacks, Section 10.10; Section 22.2], Tags 0581 and 09JF;
the field multiplication assertions are the direct calculation above.
Mathlib's Module.End.mul_eq_comp and
Module.End.mul_apply give this right-factor-first product.
These declarations do not assert that arbitrary maps with different
endpoints form one algebra, or that a formal generator presentation is
faithful.
Lemma. The endpoint product identity [fdip-0012]AGENTDRAFTED
- October 20, 2026
Lemma. The endpoint product identity [fdip-0012]AGENTDRAFTED
- October 20, 2026
For the ring-valued incidence map \(d=h^*-s^*:\mathcal F_R(V)\to \mathcal F_R(E)\) over a commutative unital ring \(R\) and fields \(f,g\in \mathcal F_R(V)\), one has \[d(fg)=(df)(h^*g)+(s^*f)(dg).\] Every factor on the right is an edge field, and the products are pointwise in \(\mathcal F_R(E)\). Equivalently, \[d(fg)=(df)(s^*g)+(s^*f)(dg)+(df)(dg).\]
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Fix an edge \(e\) and abbreviate \(f_h=f(h(e))\), \(f_s=f(s(e))\), and similarly for \(g\). Then \[\begin {aligned} (df)(e)(h^*g)(e)+(s^*f)(e)(dg)(e) &=(f_h-f_s)g_h+f_s(g_h-g_s)\\ &=f_hg_h-f_sg_s\\ &=d(fg)(e). \end {aligned}\] Equality at each edge proves the identity. Substituting \(h^*g=s^*g+dg\) gives the second formula. The proof also applies to loops, parallel edges, empty carriers and the zero ring.
This is a direct endpoint calculation. Its cyclic specialization is Lemma [fdip-0009]. The forward-difference convention is [wingate2025lattice, Section 4, Equations (4.2)-(4.3), p. 3]; that real-lattice convention is not an attribution of the general ring-valued incidence statement.
Discussion. Squares of differences [fdip-00AK]AGENTDRAFTED
- November 4, 2026
Discussion. Squares of differences [fdip-00AK]AGENTDRAFTED
- November 4, 2026
An action for a field on the four-cycle of Example [fdip-0003] sums the squares of its differences along the edges, weighted by the edge weights \(w(e)\): that sum is the discrete form of \(\int |\nabla \varphi |^2\). A pairing sums products of the values themselves, the discrete form of \(\int fg\) when each site has unit volume. Both expressions need coefficients that can be squared and added, and a sum of squares that vanishes only when every term does. Which coefficient rings admit such a sum, and what does positivity require of the weights?
Definition. Finite incidence data and real fields [fdip-0002]AGENTDRAFTED
- October 16, 2026
Definition. Finite incidence data and real fields [fdip-0002]AGENTDRAFTED
- October 16, 2026
Specialize the field modules to \(R=\mathbb R\). The finite sets \(V,E\) and endpoint maps \(s,h:E\to V\) form a finite incidence presentation; its real specialization adds the scalar order needed for positive pairings and weights. A real vertex field is a function \(f:V\to \mathbb R\), written \(f\in \mathbb R^V\) with \(\mathbb R^V=\mathcal F_{\mathbb R}(V)\) and \(\mathbb R^E=\mathcal F_{\mathbb R}(E)\).
Their counting inner products are \[\langle f,g\rangle _V=\sum _{v\in V}f(v)g(v),\qquad \langle a,b\rangle _E=\sum _{e\in E}a(e)b(e).\] These finite sums are bilinear and symmetric. A sum of squares vanishes exactly when all its entries vanish, so they are positive definite, including on the zero space when an indexing set is empty. The real field values remain continuous even though the carrier is finite.
The real incidence map is the specialization \[D=d_{\mathbb R}:\mathbb R^V\longrightarrow \mathbb R^E,\qquad (Df)(e)=f(h(e))-f(s(e)).\] Its linearity is the specialization of the ring-valued incidence map. Loops have zero incidence, and parallel edges remain distinct. For an oriented loopless graph this is the sign convention of [spielman2009effective, Section 2.1, p. 4]; the endpoint formula extends it to loops. Connectedness and positive weights are not needed to define \(D\).
A positive edge-weight function \(w:E\to \mathbb R_{>0}\) is additional data. It acts on edge fields by \((Wa)(e)=w(e)a(e)\). Different weights change the supplied data. No retained subset belongs to this definition. The alternating four-cycle of Example [fdip-0003] is one weighted instance.
For the counting inner product, Mathlib's
EuclideanSpace is the corresponding finite function space and
PiLp.inner_apply gives the sum of coordinate inner products.
These declarations concern the pairing, rather than the incidence
presentation as a whole.
Remark. Counting pairings and the Dirichlet sum [fdip-00AL]AGENTDRAFTED
- November 3, 2026
Remark. Counting pairings and the Dirichlet sum [fdip-00AL]AGENTDRAFTED
- November 3, 2026
The counting inner products are \(\int fg\) with unit volume at each site or edge. For a positive weight \(w(e)\) on each edge, \[\sum _{e\in E}w(e)\,(Df)(e)^2\] is \(\int |\nabla \varphi |^2\), and \(w(e)\) is the coupling on that edge. The Gaussian laws later in the notes need this positivity. A general commutative ring gives the difference; an order that makes a sum of squares positive is further structure.
Discussion. Differences on a cycle of sites [fdip-00AM]AGENTDRAFTED
- November 4, 2026
Discussion. Differences on a cycle of sites [fdip-00AM]AGENTDRAFTED
- November 4, 2026
Label the sites of a cycle by \(\mathbb Z/n\mathbb Z\). The difference of neighbouring values is the derivative one writes when the step has length \(1\). The product rule a difference obeys has a correction term, and on a cycle the last site is again the first: which rule holds when the shift wraps around, and what does it leave uncorrected?
Definition. Cyclic shift and forward difference [fdip-00AN]AGENTDRAFTED
- November 3, 2026
Definition. Cyclic shift and forward difference [fdip-00AN]AGENTDRAFTED
- November 3, 2026
Let \(R\) be a commutative unital ring, let \(n\ge 1\), and take \(V=\mathbb Z/n\mathbb Z\) and \(E=\{e_i:i\in V\}\), with \(s(e_i)=i\) and \(h(e_i)=i+1\). The edge-label bijection gives an \(R\)-algebra isomorphism \[j:\mathcal F_R(E)\to \mathcal F_R(V),\qquad j(a)(i)=a(e_i).\] Its inverse sends \(f\) to the edge field \(e_i\mapsto f(i)\); both preserve the pointwise operations. With the ring-valued incidence map, the cyclic shift and forward difference are \[\,(Tf)(i)=f(i+1),\qquad \Delta =jd=T-I.\] The shift is an algebra automorphism, with \(\,(T^{-1}f)(i)=f(i-1)\). Vertex and edge fields are identified only through the displayed map \(j\).
Lemma. A shifted product rule [fdip-0009]
L∃∀NAGENTDRAFTED
- October 16, 2026
Lemma. A shifted product rule [fdip-0009]
L∃∀NAGENTDRAFTED
- October 16, 2026
Let \(R\) be a commutative unital ring and let \(n\ge 1\). On \(\mathcal F_R(\mathbb Z/n\mathbb Z)\), let \(T\) and \(\Delta \) be the cyclic shift and forward difference.
For \(f,g\) in that module, \[\Delta (fg)=(\Delta f)(Tg)+f\Delta g.\] Equivalently, \[\Delta (fg)=(\Delta f)g+f\Delta g+(\Delta f)(\Delta g).\] Wingate defines forward and backward differences with lattice spacing \(a\) in [wingate2025lattice, Section 4, Equations (4.2)-(4.3), p. 3]. Here \(a=1\); the ring-valued finite identities are direct calculations, with no continuum approximation.
Proof.
- October 16, 2026
Proof.
- October 16, 2026
For every \(i\), \((jh^*f)(i)=f(i+1)=Tf(i)\) and \((js^*f)(i)=f(i)\). Applying the product-preserving map \(j\) to Lemma [fdip-0012] therefore gives the first formula, where \(j\), \(s\) and \(h\) are the isomorphism and endpoint maps of that cycle. Substitute \(Tg=g+\Delta g\) to obtain the second.
At \(n=1\), the cycle has a loop and \(T=I\), \(\Delta =0\). At \(n=2\), its two edges have opposite orientations between the same vertices; it is not a single simple edge. The unshifted Leibniz rule fails by the correction \(\,(\Delta f)(\Delta g)\). On the four-cycle, \(f=\delta _1\) satisfies \(f^2=f\); at vertex \(0\), \(\,(\Delta (f^2))(0)=1\) and \(\,((\Delta f)f+f\Delta f)(0)=0\), while \(\,((\Delta f)(Tf)+f\Delta f)(0)=1\). Lemma [fdip-0014] adds a real pairing and identifies the positive kinetic factorization.
Mathlib's fwdDiff_smul proves the three-term formula for
an additive commutative monoid, a ring and a module over it. Take the
index monoid \(\mathbb Z/n\mathbb Z\), step \(1\), and the regular
\(R\)-module \(R\). Scalar multiplication is ring multiplication.
Substituting \(Tg=g+\Delta g\) yields the shifted formula; this marker
does not claim the endpoint incidence or counting-adjoint theorem.
Lemma. Shift and multiplication operators [fdip-0013]AGENTDRAFTED
- October 20, 2026
Lemma. Shift and multiplication operators [fdip-0013]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and \(n\ge 1\) an integer. On \(\mathcal F_R(\mathbb Z/n\mathbb Z)\), let \(T\) and \(\Delta =T-I\) be the cyclic shift and forward difference, and let \(M_f\) be the multiplication operator of a field \(f\in \mathcal F_R(\mathbb Z/n\mathbb Z)\). As actual endomorphisms of this one module, \[TM_f=M_{Tf}T,\qquad \Delta M_f=M_{\Delta f}T+M_f\Delta .\]
Proof.
- October 20, 2026
Proof.
- October 20, 2026
For each field \(g\) and each residue class \(i\), \[(TM_fg)(i)=f(i+1)g(i+1)=(M_{Tf}Tg)(i).\] This proves the first equality. Since \(M_{\Delta f}=M_{Tf}-M_f\), \[\begin {aligned} M_{\Delta f}T+M_f\Delta &=(M_{Tf}-M_f)T+M_f(T-I)\\ &=M_{Tf}T-M_f\\ &=TM_f-M_f=\Delta M_f. \end {aligned}\] For \(n=1\), \(T=I\) and \(\Delta =0\), so the same identities hold.
The operator product is fixed in Proposition [fdip-0011]. For the difference convention, see [wingate2025lattice, Section 4, Equations (4.2)-(4.3), p. 3]. The proof concerns these represented maps; it asserts no universal presentation for formal generators. Example [fdip-00AP] is a clock and a shift for which the two products differ.
Example. Clock and shift [fdip-00AP]AGENTDRAFTED
- November 3, 2026
Example. Clock and shift [fdip-00AP]AGENTDRAFTED
- November 3, 2026
Let \(N\ge 1\) and let \(R\) be a commutative unital ring containing an element \(\omega \) with \(\omega ^N=1\). On \(\mathbb Z/N\mathbb Z\) set \(\chi (i)=\omega ^i\), let \(U=M_\chi \) be the multiplication operator of \(\chi \), and let \(T\) be the cyclic shift. Lemma [fdip-0013] gives \(TU=M_{T\chi }T\). Since \(\,(T\chi )(i)=\chi (i+1)=\omega ^{i+1}=\omega \chi (i)\), one has \(M_{T\chi }=\omega U\), and therefore \(TU=\omega UT\). When \(\omega \ne 1\) the two products differ. Also \(T^N=I\) and \(U^N=M_{\chi ^N}=I\). If \(\omega \) is primitive of order \(N\), the operators \(T\), \(U\) and the powers of \(\omega \) generate a finite Heisenberg group. The four-cycle is the case \(N=4\).
The continuum form is the commutator of differentiation with multiplication by the coordinate. For a smooth function \(f\), \[\frac {d}{dx}(xf)-x\frac {d}{dx}f=f,\] so \(\bigl [\tfrac {d}{dx},x\bigr ]=1\). With \(p=-i\hbar \,d/dx\) this is \([p,x]=-i\hbar \).
The same relation holds over the field \(\mathbb F_p\) when \(N\) divides \(p-1\). Then \(X^N-1\) divides \(X^{p-1}-1=\prod _{c\in \mathbb F_p^\times }(X-c)\). The divisor is separable, because \(p\) does not divide \(N\) and \(X^N-1\) shares no root with its derivative, so it has \(N\) distinct roots in \(\mathbb F_p\). Those roots form a subgroup \(G\). Let \(m\) be the least common multiple of the orders of its elements, and factor \(m\) into prime powers. For each prime power \(q\) in that factorization, some element of \(G\) has order divisible by \(q\), and a power of it has order \(q\). The product of one such element for each prime power has order \(m\): the factors commute, and their orders are coprime. Every element of \(G\) is a root of \(X^m-1\), and a field has at most \(m\) roots of that polynomial, so \(N\le m\). Orders in \(G\) divide \(N\), so \(m\) divides \(N\). Hence \(m=N\), and \(G\) contains a primitive \(N\)-th root.
Reference pairings, adjoints and parity [fdip-001N]AGENTDRAFTED
- October 20, 2026
Reference pairings, adjoints and parity [fdip-001N]AGENTDRAFTED
- October 20, 2026
To compare a field operator's input and output through a bilinear form, a reference pairing represents its adjoint. This is the return operation used later for incidence and weighted energy. The finite field module has a perfect counting pairing over any commutative unital ring. Its represented adjoint is an ordinary linear product-reversing involution; neither positivity nor division by two is required.
A partition of the carrier splits fields by restriction and extension by zero. It also separates operators that preserve the two parts from those that exchange them, giving a parity grading. The four-cycle calculation exhibits an odd invertible shift and a difference with both parity components. This distinguishes parity from the extra requirement of a square-zero differential, before paired differences and elimination of a chosen summand.
Lemma. Perfect counting duality [fdip-001F]AGENTDRAFTED
- October 20, 2026
Lemma. Perfect counting duality [fdip-001F]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring, \(V\) a finite set and \(H=\mathcal F_R(V)\) its field module. The counting bilinear form is \[b(f,g)=\sum _{v\in V}f(v)g(v).\] It is symmetric. Write \(H^\vee =\operatorname {Hom}_R(H,R)\) for the dual module, using ordinary \(R\)-linear maps: both coefficient rings are \(R\) and \(\sigma =\operatorname {id}_R\), as in Remark [ca-001G]. The perfect counting duality is the pair of inverse \(R\)-linear maps \[\begin {aligned} \Phi :H&\longrightarrow H^\vee ,&\Phi (g)(f)&=b(f,g),\\ \Psi :H^\vee &\longrightarrow H,&(\Psi \ell )(v)&=\ell (\delta _v). \end {aligned}\] Here \(\delta _v(u)\) is \(1\) when \(u=v\), and \(0\) otherwise. Perfection means precisely that \(\Phi \) is an isomorphism.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Commutativity and distributivity in \(R\) give symmetry and bilinearity of \(b\); they also give linearity of \(\Phi \) and \(\Psi \). For \(f\in H\), evaluation at every point proves \(f=\sum _v f(v)\delta _v\). Consequently \[(\Phi \Psi \ell )(f) =\sum _v f(v)\ell (\delta _v) =\ell \left (\sum _v f(v)\delta _v\right )=\ell (f).\] Conversely, \((\Psi \Phi g)(v)=b(\delta _v,g)=g(v)\). Thus both composites are identities.
This proof includes the empty set and the zero ring. It uses no order, positivity or division. A perfect form can have nonzero vectors of zero self-pairing: over \(\mathbb F_2\), the counting form on two points has \(b((1,1),(1,1))=0\). Conversely, separation of vectors alone does not imply perfection over a ring: the form \(b(x,y)=2xy\) on \(\mathbb Z\) cannot represent the functional \(x\mapsto x\). The Hom-module convention is [stacks2017stacks, Section 10.10], Tag 0581; the explicit inverse above supplies the finite counting assertion.
Definition. Ordinary linear involutions [fdip-001G]AGENTDRAFTED
- October 20, 2026
Definition. Ordinary linear involutions [fdip-001G]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and \(A\) an associative unital \(R\)-algebra. An ordinary \(R\)-linear involution on \(A\) is an \(R\)-linear map \(a\mapsto a^\dagger \), with \(\sigma =\operatorname {id}_R\), satisfying \[1^\dagger =1,\qquad (ab)^\dagger =b^\dagger a^\dagger ,\qquad (a^\dagger )^\dagger =a.\] Thus it reverses products, preserves sums and satisfies \((ra)^\dagger =ra^\dagger \). The involution on the coefficient ring is explicitly the identity.
These are ordinary product-reversal laws: no sign depending on degree occurs. Over \(\mathbb C\), this convention is bilinear and does not introduce complex conjugation. A Hermitian adjoint needs different coefficient data. Neither a grading nor freeness selects an involution; the counting adjoint below is constructed from a specified pairing.
Mathlib separates the involutive law InvolutiveStar,
product reversal StarMul, additive compatibility
StarRing and scalar compatibility StarModule.
Its starRingOfComm permits the identity involution on
a commutative ring. These interfaces support the stated convention;
the represented example requires its own proof.
For the library attribution, see [mathlib2020lean].
Example. Transpose as an ordinary involution [fdip-004A]AGENTDRAFTED
- October 31, 2026
Example. Transpose as an ordinary involution [fdip-004A]AGENTDRAFTED
- October 31, 2026
Let \(R\) be a commutative unital ring and \(A=M_n(R)\). Define \((X^T)_{ij}=X_{ji}\). This gives an ordinary linear involution: \[(rX+Y)^T=rX^T+Y^T,\qquad I^T=I,\qquad (XY)^T=Y^TX^T,\qquad (X^T)^T=X.\]
Proof.
- October 31, 2026
Proof.
- October 31, 2026
The first, second and fourth identities follow by evaluating the \((i,j)\) entry. For product reversal, commutativity gives \[\begin {aligned} ((XY)^T)_{ij}&=\sum _k X_{jk}Y_{ki}\\ &=\sum _k Y_{ki}X_{jk}=(Y^TX^T)_{ij}. \end {aligned}\] The same formulas include \(n=0\), with empty sums.
For instance, transposing \(\left (\begin {smallmatrix}a&b\\c&d\end {smallmatrix}\right )\) exchanges \(b\) and \(c\). Over \(\mathbb C\), transpose is complex-linear, whereas conjugate transpose is not: \((iI)^*=-iI\ne iI^*\) when \(n>0\). Conjugate transpose is nevertheless real-linear, so the coefficient ring matters. The counting adjoint recovers ordinary transpose from its specified bilinear pairing.
These are entrywise deductions from the definition. Mathlib's
Matrix.transpose_add, Matrix.transpose_smul,
Matrix.transpose_mul and Matrix.transpose_transpose
record the corresponding identities; see [mathlib2020lean].
Proposition. The represented counting adjoint [fdip-001H]AGENTDRAFTED
- October 20, 2026
Proposition. The represented counting adjoint [fdip-001H]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring, \(V\) a finite set and \(H=\mathcal F_R(V)\). Equip \(H\) with the perfect counting duality \(b,\Phi ,\Psi \), with \(H^\vee =\operatorname {Hom}_R(H,R)\). For \(a\in \operatorname {End}_R(H)\), define \[\begin {aligned} a^\vee :H^\vee &\longrightarrow H^\vee , &a^\vee (\ell )&=\ell \circ a,\\ a^\dagger &=\Psi \circ a^\vee \circ \Phi :H\longrightarrow H. \end {aligned}\] The counting adjoint \(a^\dagger \) is the unique ordinary \(R\)-linear endomorphism satisfying \[b(f,a^\dagger g)=b(af,g)\qquad (f,g\in H).\] It gives an ordinary \(R\)-linear involution on the composition algebra \(\operatorname {End}_R(H)\). Products act with the right factor first.
The real incidence construction in Definition [fdip-0007] starts from \(D:\mathbb R^V\to \mathbb R^E\) and returns an adjoint in the opposite direction. Here \(a:H\to H\) is an endomorphism over the commutative ring \(R\). Both use the characterizing identity that moves the operator between the two counting-pairing slots. The existence and laws below follow from Lemma [fdip-001F], independently of the real incidence proof.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
The composite \(\ell \circ a\) is linear, and precomposition is linear in \(\ell \); thus all three arrows defining \(a^\dagger \) are linear. Since \(\Phi \Psi =I\), evaluation at \(f\) gives the displayed adjoint identity. Injectivity of \(\Phi \) gives uniqueness for each \(g\). In particular, \[(a^\dagger g)(v)=b(a\delta _v,g).\] For \(a,c\in \operatorname {End}_R(H)\) and \(r\in R\), bilinearity and uniqueness give \[(a+c)^\dagger =a^\dagger +c^\dagger ,\quad (ra)^\dagger =ra^\dagger ,\quad I^\dagger =I.\] Indeed the right-hand sides represent respectively \(b((a+c)f,g)\), \(b((ra)f,g)\) and \(b(f,g)\).
For products, applying the defining identity twice yields \[b(f,c^\dagger a^\dagger g) =b(cf,a^\dagger g)=b(acf,g),\] so \((ac)^\dagger =c^\dagger a^\dagger \). Symmetry of \(b\) gives \[\begin {aligned} b(f,(a^\dagger )^\dagger g) &=b(a^\dagger f,g)=b(g,a^\dagger f)\\ &=b(ag,f)=b(f,ag). \end {aligned}\] Uniqueness therefore gives \((a^\dagger )^\dagger =a\).
The construction also applies when \(V\) is empty or \(R\) is the zero ring. Its representability is supplied by the explicit inverse to \(\Phi \), not by a field hypothesis or a positivity argument. Dual precomposition reverses composition before any pairing is chosen; the Hom convention is [stacks2017stacks, Section 10.10], Tag 0581. The proof here adds the specified symmetric counting identification with the dual.
Lemma. A partition splits the field module [fdip-001I]AGENTDRAFTED
- October 20, 2026
Lemma. A partition splits the field module [fdip-001I]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and choose a partition \(V=V_0\sqcup V_1\) of a finite set. Put \(H=\mathcal F_R(V)\) and \(K_i=\mathcal F_R(V_i)\) for \(i=0,1\). Restriction and extension by zero are ordinary \(R\)-linear maps \[\pi _i:H\to K_i,\qquad \iota _i:K_i\to H,\] with \((\pi _i f)(v)=f(v)\) for \(v\in V_i\), and \((\iota _i u)(v)=u(v)\) on \(V_i\), zero elsewhere. The support submodules are \(H_i=\iota _i(K_i)\subseteq H\). The support projections \(p_i=\iota _i\pi _i:H\to H\) satisfy \[\pi _i\iota _i=I_{K_i},\quad \pi _i\iota _j=0\ (i\ne j),\quad p_i^2=p_i,\quad p_ip_j=0\ (i\ne j),\quad p_0+p_1=I_H.\] Every \(f\in H\) has a unique expression \(f=f_0+f_1\) with \(f_i\in H_i\), namely \(f_i=p_if\).
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Evaluation at a point proves linearity and all the displayed composition identities. A field belongs to \(H_i\) precisely when it vanishes outside \(V_i\). Thus \(H_0\cap H_1=\{0\}\). The identity \(p_0+p_1=I_H\) gives existence of the decomposition. If \(f_0+f_1=g_0+g_1\), then \(f_0-g_0=g_1-f_1\in H_0\cap H_1\), proving uniqueness.
The partition is additional data, not part of the general incidence-field definition. If one part is empty, its field module and support projection are zero. Nothing requires division by \(2\); the same construction works in characteristic \(2\) and over the zero ring. This is the direct finite-function realization of a module decomposition.
[stacks2017stacks, Section 10.10], Tag 0581 supplies the module convention.
Definition. Internal parity grading [fdip-001J]AGENTDRAFTED
- October 20, 2026
Definition. Internal parity grading [fdip-001J]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and \(A\) an associative unital \(R\)-algebra. An internal parity grading consists of \(R\)-submodules \(A_0,A_1\subseteq A\), with operations inherited from \(A\), such that every \(a\in A\) has a unique decomposition \(a=a_0+a_1\), with \(a_i\in A_i\), and \[1\in A_0,\qquad A_iA_j\subseteq A_{i+j}.\] Subscripts are added in \(\mathbb Z/2\mathbb Z\). An element of \(A_i\) is homogeneous of parity \(i\); parity \(0\) is even and parity \(1\) is odd. The zero element lies in both submodules. Scalars \(r1\) belong to \(A_0\).
The multiplication condition controls the component of a product; it does not require \(ab=(-1)^{ij}ba\) for \(a\in A_i\), \(b\in A_j\). Nor does it require an odd element to square to zero. Those are additional equations, tested explicitly by the four-cycle.
The internal-submodule viewpoint and multiplication rule follow
[wieser2022graded, Section 1, accepted-manuscript pp. 1-2],
here specialized to the index group \(\mathbb Z/2\mathbb Z\).
Mathlib's GradedRing and GradedAlgebra encode
graded multiplication and compatible scalar data. The chosen
operator decomposition still needs the proof in
Proposition [fdip-001K].
Proposition. Parity of field endomorphisms [fdip-001K]AGENTDRAFTED
- October 20, 2026
Proposition. Parity of field endomorphisms [fdip-001K]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring, \(V=V_0\sqcup V_1\) a finite partition, and \(H=\mathcal F_R(V)\). Use its support submodules \(H_i\) and support projections \(p_i\). All subscripts below are in \(\mathbb Z/2\mathbb Z\). For \(A=\operatorname {End}_R(H)\) with composition product, put \[A_k=\{a\in A:a(H_i)\subseteq H_{i+k}\text { for }i=0,1\}.\] These submodules give an internal parity grading. The two components of \(a\in A\) are \[a_0=p_0ap_0+p_1ap_1,\qquad a_1=p_1ap_0+p_0ap_1.\] All products are compositions of maps \(H\to H\); these formulas require no choice of ordered basis.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Each \(A_k\) is a submodule because \(H_{i+k}\) is a submodule. For \(f\in H_i\), the projection identities show that \(a_kf=p_{i+k}af\in H_{i+k}\), so \(a_k\in A_k\). Expanding \((p_0+p_1)a(p_0+p_1)\) gives \(a=a_0+a_1\). If \(a\in A_0\cap A_1\), its value on \(H_i\) belongs to \(H_i\cap H_{i+1}=\{0\}\). Every field is a sum of such inputs, so \(a=0\). This proves uniqueness of the two components.
The identity preserves each \(H_i\), hence lies in \(A_0\). If \(a\in A_k\) and \(c\in A_l\), then \(c(H_i)\subseteq H_{i+l}\) and \(a(H_{i+l})\subseteq H_{i+l+k}\). Thus \(ac\in A_{k+l}\), proving the multiplication rule.
If one part is empty, \(A_1=0\); if both parts are empty, the whole algebra is zero. The argument also allows the zero ring and characteristic \(2\). Graded endomorphism composition appears in [stacks2017stacks, Section 22.25, Example 22.25.5], Tag 09L1. That example is integer-graded; the direct proof here establishes the two-parity, finite-function instance.
Lemma. Adjoints preserve the chosen parity [fdip-001L]AGENTDRAFTED
- October 20, 2026
Lemma. Adjoints preserve the chosen parity [fdip-001L]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and \(V=V_0\sqcup V_1\) a finite partition. Equip \(H=\mathcal F_R(V)\) with its counting pairing \(b\), counting adjoint constructed in Proposition [fdip-001H], and parity grading \(A_0,A_1\) on \(\operatorname {End}_R(H)\). Then \(p_i^\dagger =p_i\) for the support projections, and \[a\in A_k\quad \Longrightarrow \quad a^\dagger \in A_k.\] Every multiplication operator \(M_f\), for \(f\in H\), is even and satisfies \(M_f^\dagger =M_f\).
Proof.
- October 20, 2026
Proof.
- October 20, 2026
For \(u,v\in H\), restriction of the counting sum gives \[b(p_iu,v)=\sum _{x\in V_i}u(x)v(x)=b(u,p_iv),\] so uniqueness of the adjoint gives \(p_i^\dagger =p_i\). The support summands are orthogonal: if \(u\in H_0\) and \(v\in H_1\), every term of \(b(u,v)\) is zero.
For \(a\in A_k\), evaluation on each support summand gives \[a=\sum _{i=0}^1p_{i+k}ap_i.\] Taking the ordinary adjoint, including its linearity and product reversal, yields \[a^\dagger =\sum _{i=0}^1p_i a^\dagger p_{i+k}.\] Each summand maps \(H_{i+k}\) into \(H_i\) and vanishes on the other support summand. Its degree is \(-k=k\) in \(\mathbb Z/2\mathbb Z\), proving the claim.
Multiplication by a field preserves support, so \(M_f\in A_0\). Commutativity of \(R\) gives \[b(M_fu,v)=\sum _x f(x)u(x)v(x)=b(u,M_fv).\] Uniqueness therefore gives \(M_f^\dagger =M_f\).
The degree statement depends on this orthogonal support decomposition and this symmetric counting pairing. It is not a law for an unspecified grading and involution. The involution on coefficients is the identity, including for complex coefficients; no Hermitian or positive conclusion is inferred. The graded composition convention is [stacks2017stacks, Section 22.25], Tag 09L1; the compatibility with the chosen pairing is proved above.
Example. Parity and adjoint on the four-cycle [fdip-001M]AGENTDRAFTED
- October 20, 2026
Example. Parity and adjoint on the four-cycle [fdip-001M]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring. On the four-cycle, take \(V=\mathbb Z/4\mathbb Z\), \(H=\mathcal F_R(V)\) and the additional partition \(V_0=\{0,2\}\), \(V_1=\{1,3\}\). The cyclic shift \(T:H\to H\) is \((Tf)(i)=f(i+1)\). It exchanges the two support submodules: if \(f\) is supported on \(V_j\), then \(Tf\) is supported on \(V_{j+1}\). Hence \(T\) is odd in the chosen operator grading.
For the counting adjoint constructed over \(R\) in Proposition [fdip-001H], reindexing the finite sum proves \[b(Tf,g)=\sum _i f(i+1)g(i) =\sum _j f(j)g(j-1)=b(f,T^{-1}g),\] so \(T^\dagger =T^{-1}\). Also \(T^4=I\); thus the half-turn \(T^2\) is even and satisfies \((T^2)^\dagger =T^{-2}=T^2\). These unweighted counting identities do not assert that the one-step shift preserves the alternating weights. The weight-preserving half-turn and the one-step counterexample remain those in Example [fdip-0003].
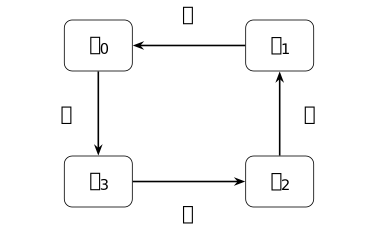
The arrows show the action on basis fields, opposite to the source-to-head orientation on vertices. Every arrow switches support parity; two steps give the half-turn. In particular, over \(\mathbb Z\), \(T^2\delta _0=\delta _2\ne 0\). Thus an odd operator need not square to zero. It need not satisfy a graded commutation law either: that law applied to \(T,T\) would give \(2T^2=0\), whereas \(2T^2\delta _0=2\delta _2\ne 0\).
Identify edge \(i\) with vertex \(i\), with source \(i\) and head \(i+1\), as in Lemma [fdip-0009]. Only after this identification does incidence become the endomorphism \(\Delta =T-I\). Its even component is \(-I\) and its odd component is \(T\). Over \(\mathbb Z\), both are nonzero, so \(\Delta \) is inhomogeneous, and \[\Delta ^2\delta _0=\delta _2-2\delta _3+\delta _0\ne 0.\] The formulas remain valid over every commutative unital ring, but the nonzero witnesses just used are specifically over \(\mathbb Z\); in the zero ring all these fields and maps vanish. This is a direct specialization of the shift-multiplication realization and partition construction, not a square-zero differential supplied by parity.
[wieser2022graded, Section 1, accepted-manuscript pp. 1-2] gives the grading convention; the shift, adjoint and failure witnesses are the computations here.
Pairings and discrete differences [fdip-0016]AGENTDRAFTED
- October 20, 2026
Pairings and discrete differences [fdip-0016]AGENTDRAFTED
- October 20, 2026
How can an edge difference return to a vertex field, and when does its energy detect a constant field? The finite field modules and counting duality give a concrete starting point. Chosen perfect symmetric pairings extend the adjoint construction to different modules over a commutative ring. Applied to incidence, they give weighted energy and the cyclic kinetic factorization.
The component-kernel theorem identifies the additional role of positive real weights; a characteristic-two example shows why perfection alone is insufficient. An invertible precision then gives a unique response to each source, before any probability interpretation.
Definition. Chosen perfect symmetric pairings [fdip-001O]AGENTDRAFTED
- October 20, 2026
Definition. Chosen perfect symmetric pairings [fdip-001O]AGENTDRAFTED
- October 20, 2026
The perfect counting duality represents every linear functional by a unique field. To make the same construction on another carrier, let \(R\) be a commutative unital ring and \(M\) a unital \(R\)-module. Write \(M^\vee =\operatorname {Hom}_R(M,R)\) for its dual module. Every linear map here has coefficient map \(\operatorname {id}_R\), as in Remark [ca-001G].
A chosen perfect symmetric pairing on \(M\) is a
bilinear form \(b_M:M\times M\to R\) such that
\(b_M(x,y)=b_M(y,x)\) and the linear map
\[\Phi _M:M\longrightarrow M^\vee ,\qquad
\Phi _M(y)(x)=b_M(x,y)\]
is an isomorphism. Thus each functional \(\ell \)
has exactly one representative \(\Phi _M^{-1}\ell \), characterized by
\(b_M(x,\Phi _M^{-1}\ell )=\ell (x)\) for every \(x\). Bilinearity makes
\(\Phi _M\) linear. Symmetry identifies the other currying map
\(y\mapsto (x\mapsto b_M(y,x))\) with \(\Phi _M\), so both are
isomorphisms. This agrees with the two-sided perfect-pairing convention
in Mathlib's LinearMap.IsPerfPair. The ordinary Hom convention
is [stacks2017stacks, Section 10.10], Tag 0581.
Injectivity alone says that \(b_M(x,y)=0\) for every \(x\) forces \(y=0\); symmetry gives the analogous assertion in the other slot. It does not give every functional a representative; see a zero-radical pairing that is not perfect.
No finiteness, basis or projectivity hypothesis is imposed on \(M\); the specified duality is the assumption. The counting form on every finite function module satisfies it by the explicit inverse in Lemma [fdip-001F]. The zero module has its unique perfect pairing. If \(R\) is the zero ring, every unital module is zero since \(x=1x=0x=0\), so this case is included. Perfection does not assert positivity or determine a bilinear form from its diagonal values.
Example. A zero-radical pairing that is not perfect [fdip-001S]AGENTDRAFTED
- October 20, 2026
Example. A zero-radical pairing that is not perfect [fdip-001S]AGENTDRAFTED
- October 20, 2026
On the free rank-one \(\mathbb Z\)-module \(M=\mathbb Z\), the symmetric bilinear form \(b(x,y)=2xy\) separates vectors in both slots but is not a perfect pairing. Its currying map is \[\Phi :\mathbb Z\longrightarrow \operatorname {Hom}_{\mathbb Z} (\mathbb Z,\mathbb Z),\qquad \Phi (y)(x)=2xy.\]
If \(b(x,y)=0\) for every integer \(x\), testing against \(x=1\) gives \(2y=0\), hence \(y=0\). Symmetry gives the same conclusion in the other slot, so both radicals are zero and \(\Phi \) is injective. Every integer-linear functional \(\ell \) on \(\mathbb Z\) satisfies \(\ell (x)=x\ell (1)\), so it is determined by its value at \(1\). But \(\Phi (y)(1)=2y\) is even for every \(y\). Thus \(\Phi \) misses the linear functional \(x\mapsto x\), whose value at \(1\) is \(1\), and is not surjective. Freeness of \(M\) does not repair this failure of the chosen form.
The Hom convention is [stacks2017stacks, Section 10.10], Tag 0581; the calculation above proves the failure for this chosen form. For the perfect counting form and its explicit inverse, see Lemma [fdip-001F].
Proposition. Adjoints from chosen dualities [fdip-001P]AGENTDRAFTED
- October 20, 2026
Proposition. Adjoints from chosen dualities [fdip-001P]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring and let \(M,N,P\) be unital \(R\)-modules with chosen perfect symmetric pairings \(b_M,b_N,b_P\) and duality maps \(\Phi _M,\Phi _N,\Phi _P\). For an ordinary \(R\)-linear map \(A:M\to N\), precomposition defines \[A^\vee :N^\vee \longrightarrow M^\vee ,\qquad A^\vee \ell =\ell \circ A.\] Its adjoint for chosen perfect pairings is \[A^\dagger =\Phi _M^{-1}A^\vee \Phi _N:N\longrightarrow M.\] Products denote composition, with the right factor first, as in composition and field multiplication. This is the unique linear map satisfying \[b_M(x,A^\dagger y)=b_N(Ax,y)\qquad (x\in M,\ y\in N).\]
For \(A,A':M\to N\), \(B:N\to P\) and \(r\in R\), \[\begin {aligned} (A+A')^\dagger &=A^\dagger +(A')^\dagger ,& (rA)^\dagger &=rA^\dagger ,\\ 0^\dagger &=0,&I_M^\dagger &=I_M,\\ (BA)^\dagger &=A^\dagger B^\dagger ,& (A^\dagger )^\dagger &=A. \end {aligned}\] If \(A\) is an isomorphism, then \(A^\dagger \) is an isomorphism and \[(A^{-1})^\dagger =(A^\dagger )^{-1}.\] An endomorphism \(L:M\to M\) is self-adjoint for this pairing when \(L^\dagger =L\). In particular, the inverse of an invertible self-adjoint endomorphism is self-adjoint.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
The composite \(\ell \circ A\) is linear. Evaluation at \(x\) gives \[\begin {aligned} A^\vee (\ell +k)(x)&=\ell (Ax)+k(Ax),\\ A^\vee (r\ell )(x)&=r\ell (Ax). \end {aligned}\] Hence \(A^\vee \) is linear, and so is the composite defining \(A^\dagger \). Also \((BA)^\vee =A^\vee B^\vee \) and \(I^\vee =I\), since both sides have the same value on every functional and argument. Because \(\Phi _M\Phi _M^{-1}=I\), \[b_M(x,A^\dagger y)=(A^\vee \Phi _Ny)(x)=b_N(Ax,y).\] If \(K:N\to M\) has the same identity, then \(\Phi _M(Ky)=\Phi _M(A^\dagger y)\) for every \(y\). Injectivity gives \(K=A^\dagger \); existence also used surjectivity of \(\Phi _M\).
Bilinearity shows that \(A^\dagger +(A')^\dagger \), \(rA^\dagger \), \(0\) and \(I_M\) represent the identities for \(A+A'\), \(rA\), \(0\) and \(I_M\), respectively. Uniqueness proves the 4 stated laws. For composition, apply the adjoint identity twice: \[\begin {aligned} b_M(x,A^\dagger B^\dagger z) &=b_N(Ax,B^\dagger z)\\ &=b_P(BAx,z). \end {aligned}\] This proves the product-reversal law. Symmetry gives \[\begin {aligned} b_N(y,Ax)&=b_N(Ax,y)\\ &=b_M(x,A^\dagger y)=b_M(A^\dagger y,x). \end {aligned}\] Thus \(A\) is the adjoint of \(A^\dagger \), proving involution.
Finally, adjointing \(AA^{-1}=I_N\) and \(A^{-1}A=I_M\) gives \[(A^{-1})^\dagger A^\dagger =I_N,\qquad A^\dagger (A^{-1})^\dagger =I_M.\] These are the two inverse identities. If \(A^\dagger =A\), they identify \((A^{-1})^\dagger \) with \(A^{-1}\). No order or division is used.
In particular, for \(d:M\to N\) and a self-adjoint \(W:N\to N\), the composite \(L=d^\dagger Wd:M\to M\) satisfies \[L^\dagger =d^\dagger W^\dagger d=L,\qquad b_M(f,Lg)=b_N(df,Wdg).\] The first equality uses product reversal and double adjunction; the second is the characterizing identity for \(d\). Taking \(g=f\) gives its energy identity, without any order assumption on \(R\).
For a finite function module with its counting form, \(\Phi ^{-1}=\Psi \) from Lemma [fdip-001F]; the formula is exactly \(\Psi A^\vee \Phi \) from Proposition [fdip-001H]. Hence it gives the same ordinary \(R\)-linear involution on endomorphisms. The proof above extends that direct construction to different carriers.
The Hom convention is [stacks2017stacks, Section 10.10], Tag 0581.
TauCeti's Module.dualEndAlgEquiv expresses
reversed dual composition for reflexive modules. It concerns dual
endomorphisms, before the chosen symmetric identifications used here.
Mathlib's LinearMap.BilinForm.toDual constructs a duality
from a nondegenerate form in the finite-dimensional field case.
Here the dualities are explicitly assumed over \(R\); the argument above
proves the resulting adjoint laws. A nontrivial coefficient involution
and Hermitian forms require different scalar conventions.
Definition. Weighted graph differentials and adjoints [fdip-0007]AGENTDRAFTED
- October 16, 2026
Definition. Weighted graph differentials and adjoints [fdip-0007]AGENTDRAFTED
- October 16, 2026
Let \(R\) be a commutative unital ring, \(V,E\) finite sets and \(s,h:E\to V\) endpoint maps. The ring-valued incidence map is \(d_R:H_V\to H_E\), where \(H_V=\mathcal F_R(V)\), \(H_E=\mathcal F_R(E)\) and \(d_Rf(e)=f(h(e))-f(s(e))\). Equip both modules with the symmetric counting forms \[b_V(f,g)=\sum _v f(v)g(v),\qquad b_E(a,c)=\sum _e a(e)c(e).\] Their perfect counting dualities give the counting adjoint \(d_R^\dagger :H_E\to H_V\) by Proposition [fdip-001P]. It is characterized by \(b_E(d_Rf,a)=b_V(f,d_R^\dagger a)\).
The return map can be read directly from the endpoints: \[(d_R^\dagger a)(v) =\sum _{h(e)=v}a(e)-\sum _{s(e)=v}a(e).\]
Proof.
- October 16, 2026
Proof.
- October 16, 2026
Expanding and regrouping finite sums gives \[\begin {aligned} b_E(d_Rf,a) &=\sum _e\bigl (f(h(e))-f(s(e))\bigr )a(e)\\ &=\sum _v f(v)\left (\sum _{h(e)=v}a(e)-\sum _{s(e)=v}a(e)\right ). \end {aligned}\] This is the characterizing identity, so uniqueness identifies the map. Each loop occurs once in both sums and cancels; parallel edges remain separate summands. If \(V\) is empty, existence of \(s:E\to V\) forces \(E\) empty; the formula gives the unique map of zero modules.
For arbitrary weights \(w:E\to R\), let \(W:H_E\to H_E\) multiply pointwise by \(w\): \((Wa)(e)=w(e)a(e)\). The weighted graph Laplacian is \[L=d_R^\dagger Wd_R:H_V\longrightarrow H_V.\] Commutativity makes \(W\) self-adjoint, since \(b_E(Wa,c)=\sum _e w(e)a(e)c(e)=b_E(a,Wc)\). The weighted edge form \[b_{E,w}(a,c)=b_E(a,Wc)=\sum _e w(e)a(e)c(e)\] is symmetric bilinear. It is perfect if and only if every \(w(e)\) is a unit, meaning an invertible element of \(R\).
Proof.
- October 16, 2026
Proof.
- October 16, 2026
Its duality map is \(\Phi _EW\). Since \(\Phi _E\) is an isomorphism, \(\Phi _EW\) is an isomorphism exactly when \(W\) is. If every weight is a unit, multiplication by \(w(e)^{-1}\) gives both inverse identities pointwise. Conversely, if \(WJ=I\), evaluate \(WJ\delta _e=\delta _e\) at \(e\): \[w(e)(J\delta _e)(e)=1.\] Commutativity supplies the other inverse identity for this scalar, so \(w(e)\) is a unit. For \(E=\varnothing \), the unit condition is vacuous and \(W\) is the unique isomorphism of the zero module. In the zero ring, \(0=1\) is itself a unit, consistent with the same proof.
Even when some weights are nonunits, the represented return map \(d_R^\dagger W\) exists and satisfies \[b_{E,w}(d_Rf,a)=b_V(f,d_R^\dagger Wa).\] Its existence does not make the weighted edge form perfect. Thus it does not by itself give a two-sided adjoint involution for that form. All these ring identities are direct deductions from the chosen counting dualities. Their positive-real incidence convention is [spielman2009effective, Section 2.1, p. 4].
Orientation reversal leaves \(L\) unchanged. Choose which edges to reverse, and put \(\varepsilon (e)=-1\) on those edges and \(1\) on the others, interpreted in \(R\). The sign map \(Ja(e)=\varepsilon (e)a(e)\) satisfies \(J^\dagger =J\), \(J^2=I\), \(JW=WJ\), and the reversed incidence map is \(d'_R=Jd_R\). Therefore \[(d'_R)^\dagger Wd'_R=d_R^\dagger JWJd_R=d_R^\dagger Wd_R.\] The corresponding edge field is \(a'=Ja\), and \(b_{E,w}(Ja,Jc)=b_{E,w}(a,c)\). The proof includes characteristic two, loops and parallel edges. Endpoints and weights are otherwise fixed.
For the real incidence adapter, start with the incidence map \(D:\mathbb R^V\to \mathbb R^E\) and positive weights \(w(e)>0\). The counting forms are the counting inner products, and write \(D^*=d_{\mathbb R}^\dagger \). The edge form becomes the weighted inner product \[\langle a,c\rangle _{E,w}=\sum _e w(e)a(e)c(e).\] It is symmetric bilinear, and its self-pairing is a finite sum of nonnegative terms. Strictly positive weights make that sum zero only at the zero edge field. Keeping the vertex pairing counting, the weighted adjoint is \(D_w^\dagger =D^*W\), since \[\langle Df,a\rangle _{E,w} =\langle Df,Wa\rangle _E=\langle f,D^*Wa\rangle _V.\] Hence \(L=D^*WD=D_w^\dagger D\); \(D^*D\) is the unit-weight case.
For the coordinate recovery, use the ordered-value isomorphisms \(c_V,c_E\) and incidence matrix \(B=c_EDc_V^{-1}\). The endpoint return formula gives \(c_VD^*c_E^{-1}=B^T\). The multiplication map \(W\) has diagonal array \(\operatorname {diag}(w(e))\); writing the same letter for that array yields \([D_w^\dagger ]=B^TW\) and \([L]=B^TWB\). For a single edge \(0\to 1\) of weight \(c>0\), the two adjoints send an edge value \(a\) to \((-a,a)\) and \((-ca,ca)\), respectively. Under orientation reversal the sign array \(S\) gives \(B'=SB\), \(S^T=S\), \(S^2=I\), \(SWS=W\), and \((B')^TWB'=B^TWB\). A loop has a zero incidence row before and after reversal.
Mathlib's LinearMap.toMatrix_adjoint identifies adjoint
matrices with conjugate transposes in orthonormal bases. Over the reals
this is transpose. The coordinate edge basis is orthonormal for counting,
but not generally for the weighted pairing; the return-map calculation
above accounts for the extra \(W\).
Example. The weighted four-cycle Laplacian [fdip-004B]AGENTDRAFTED
- October 31, 2026
Example. The weighted four-cycle Laplacian [fdip-004B]AGENTDRAFTED
- October 31, 2026
Use the alternating four-cycle, with vertices \(0,1,2,3\), edges \(e_i:i\to i+1\), and positive real weights \((1,t,1,t)\). For a field \(f=(a,b,c,d)\), the incidence values are \(Df=(b-a,c-b,d-c,a-d)\). The counting adjoint sends an edge field to \[D^*(u_0,u_1,u_2,u_3) =(u_3-u_0,u_0-u_1,u_1-u_2,u_2-u_3).\] First multiply by \(W_t=\operatorname {diag}(1,t,1,t)\), then apply \(D^*\). The resulting \(L_t=D^*W_tD\) has coordinate matrix \[L_t=\begin {pmatrix} 1+t&-1&0&-t\\ -1&1+t&-t&0\\ 0&-t&1+t&-1\\ -t&0&-1&1+t \end {pmatrix}.\]
For example, its first coordinate is \(t(a-d)-(b-a)=(1+t)a-b-td\); the other coordinates follow from the same return formula. Thus \[L_t\delta _0=(1+t,-1,0,-t),\qquad L_t\mathbf 1=0,\] and the counting energy is \[\langle f,L_tf\rangle =(b-a)^2+t(c-b)^2+(d-c)^2+t(a-d)^2.\] The counting adjoint \(D^*\) does not depend on \(t\). The weighted return map \(D^*W_t\), and hence \(L_t\), do. When \(t=1\) the two return maps coincide; otherwise the factors \(t\) must be retained.
This calculation substitutes the four-cycle data into Definition [fdip-0007]; its incidence convention follows [spielman2009effective, Section 2.1, p. 4]. The cyclic energy factorization gives the corresponding operator identity.
Lemma. Counting adjoints on an indexed cycle [fdip-0014]AGENTDRAFTED
- October 20, 2026
Lemma. Counting adjoints on an indexed cycle [fdip-0014]AGENTDRAFTED
- October 20, 2026
Let \(R\) be a commutative unital ring. Take the cyclic shift on \(\mathcal F_R(\mathbb Z/n\mathbb Z)\), \(n\ge 1\), with its perfect counting duality \(b\). For the counting adjoint, write \(A^*=A^\dagger \). Then \[T^*=T^{-1},\qquad \Delta ^*=T^{-1}-I.\] Writing \(\nabla ^-=I-T^{-1}\) for the backward difference gives \[\Delta ^*\Delta =-\nabla ^-\Delta =2I-T-T^{-1}.\] Here \(2=1+1\); its invertibility is not required. For the real difference and kinetic signs, see [wingate2025lattice, Section 4, Equations (4.3) and (4.5), p. 3], with lattice spacing one. The finite periodic ring identities follow by reindexing, independently of the product rule.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
The substitution \(j=i+1\) permutes the finite index set, so \[\begin {aligned} b(Tf,g)&=\sum _i f(i+1)g(i)\\ &=\sum _j f(j)g(j-1)=b(f,T^{-1}g). \end {aligned}\] Uniqueness of the counting adjoint gives \(T^*=T^{-1}\). Subtracting \(b(f,g)\) gives \(b(\Delta f,g)=b(f,(T^{-1}-I)g)\), so \(\Delta ^*=T^{-1}-I\). Multiplication gives \[(T^{-1}-I)(T-I)=2I-T-T^{-1}=-\nabla ^-\Delta .\] Consequently \(b(f,\Delta ^*\Delta f)=b(\Delta f,\Delta f)\). Over \(\mathbb R\) this counting form is the counting inner product, and the last expression is \(\sum _i(\Delta f(i))^2\ge 0\).
For the indexed cycle \(e_i:i\to i+1\), the edge-label isomorphism \(j(a)(i)=a(e_i)\) of the cyclic shift and edge-label identification preserves counting pairings: \(b_V(ja,jc)=\sum _i a(e_i)c(e_i)=b_E(a,c)\). Taking \(c=j^{-1}f\) shows that \(j^*=j^{-1}\), hence \(j^*j=I\). Thus \(\Delta =jd_R\) and \[\Delta ^*\Delta =d_R^\dagger j^*j d_R=d_R^\dagger d_R,\] the unit-weight graph Laplacian. At \(n=2\), the two oppositely oriented edges give \(b(f,d_R^\dagger d_Rf)=2(f(1)-f(0))^2\); they are not one simple edge. At \(n=1\), there is one loop, \(T=I\), and both incidence and kinetic maps vanish. An arbitrary incidence map still has distinct vertex and edge carriers; this factorization does not assert that \(\Delta \) is skew-adjoint or square-zero.
Theorem. Graph energy and the constant modes [fdip-0008]AGENTDRAFTED
- October 16, 2026
Theorem. Graph energy and the constant modes [fdip-0008]AGENTDRAFTED
- October 16, 2026
Let \(R\) be a commutative unital ring, \(V,E,s,h\) finite incidence data and \(w:E\to R\) arbitrary weights. With the counting forms and weighted graph Laplacian \(L=d_R^\dagger Wd_R\), one has \[L^\dagger =L,\qquad b_V(f,Lg)=\sum _e w(e)(d_Rf)(e)(d_Rg)(e).\] The kernel of \(d_R\) consists exactly of fields constant on each connected component of the underlying undirected graph, and \(\ker d_R\subseteq \ker L\). Two vertices are in the same component when a finite path joins them, with edge orientation ignored.
Proof.
- October 16, 2026
Proof.
- October 16, 2026
The weight map is self-adjoint. The adjoint laws give \(L^\dagger =d_R^\dagger W^\dagger d_R=L\), and the defining identity gives \[\begin {aligned} b_V(f,Lg)&=b_E(d_Rf,Wd_Rg)\\ &=\sum _e w(e)(d_Rf)(e)(d_Rg)(e). \end {aligned}\] In particular, \(b_V(f,Lf)=\sum _e w(e)(d_Rf)(e)^2\). Each edge occurs once and no factor \(1/2\) is used. The equality \(d_Rf=0\) says that endpoint values agree along every edge, hence along every path. Conversely, a componentwise constant field has zero difference on each edge. This identifies \(\ker d_R\) with the function module on the components. Such a field also satisfies \(Lf=d_R^\dagger W0=0\).
The energy is unchanged by edge-orientation reversal: each reversed edge negates both factors in its summand. Equivalently, the orientation-invariant return composite gives the same Laplacian.
Perfection and unit weights do not give the reverse kernel inclusion. Over \(\mathbb F_2\), take two vertices \(0,1\) and two distinct edges, both oriented \(0\to 1\), both of weight \(1\). The counting pairings are perfect and \(W=I\) is invertible. Nevertheless, \[\begin {aligned} d_R(a,b)&=(b-a,b-a),\\ d_R^\dagger (u_1,u_2)&=(-u_1-u_2,u_1+u_2),\\ L(a,b)&=(0,0). \end {aligned}\] For \(\delta _1=(0,1)\), one has \(d_R\delta _1=(1,1)\ne 0\), but its energy is \(1+1=0\). Hence \(\ker L=\mathbb F_2^2\) strictly contains \(\ker d_R=\{(a,a):a\in \mathbb F_2\}\). This failure comes from the absence of real positivity, not from nonunit weights or nonperfect forms.
Now specialize to \(R=\mathbb R\) and \(w(e)>0\). Write \(D=d_{\mathbb R}\). The Laplacian is symmetric and positive semidefinite, and \[\ker L=\ker D,\qquad \dim \ker L=k,\] where \(k\) is the number of connected components. The energy convention and connected-graph argument appear in [spielman2009effective, Section 2.1, pp. 4-5]; the ring identity above and the disconnected, loop and parallel-edge extensions are proved directly here.
Proof.
- October 16, 2026
Proof.
- October 16, 2026
The energy identity specializes to \[\langle f,Lf\rangle _V=\sum _e w(e)(Df)(e)^2\ge 0.\] If \(Lf=0\), this finite sum of nonnegative real terms is zero. Every summand is therefore zero; strict positivity of \(w(e)\) gives \(Df(e)=0\). The reverse inclusion was proved over \(R\). Indicators of the nonempty components span the componentwise constant fields. In a linear relation between them, evaluation at a vertex of any one component makes its coefficient zero. Thus they are a basis, proving the dimension statement. An action defined as half this quadratic form uses a separate convention.
If \(V\) is nonempty and connected, the kernel is the one-dimensional space spanned by the constant field \(\mathbf 1_V\). Its positive unit mode is \[|V|^{-1/2}\mathbf 1_V.\] An isolated vertex contributes one component and one kernel basis vector. If \(V\) is empty, the maps \(s,h:E\to V\) force \(E\) to be empty too: both the component count and kernel dimension are zero. Loops contribute zero energy, while distinct parallel edges each contribute their own positive summand.
For the alternating four-cycle, put \(u=1+t\). Direct multiplication gives \[L_t=\begin {pmatrix} u&-1&0&-t\\ -1&u&-t&0\\ 0&-t&u&-1\\ -t&0&-1&u \end {pmatrix}.\] For \(f=(a,b,c,d)\), the energy is \[\begin {aligned} f^TL_tf={}&(b-a)^2+t(c-b)^2\\ &+(d-c)^2+t(a-d)^2. \end {aligned}\] Every row of \(L_t\) sums to zero, and for \(t>0\) zero energy forces all 4 values equal. The comparison with the positive action identifies how this edge energy combines with a mass term.
The hypotheses have concrete consequences. With vertices \(0,1,2,3\) and just the unit-weight edges \(0\to 1\) and \(2\to 3\), the matrix has two diagonal blocks \(\bigl (\begin {smallmatrix}1&-1\\-1&1\end {smallmatrix}\bigr )\). Its kernel is \(\{(a,a,b,b):a,b\in \mathbb R\}\); connectivity is needed for a single constant mode.
On two vertices with one edge \(0\to 1\) of weight zero, the underlying graph is connected but \(L=0\), so its kernel is all of \(\mathbb R^2\). For nonnegative weights the same proof identifies the kernel using only the positive-weight edges. A zero weight also makes the proposed edge pairing degenerate. If instead this edge has weight \(-1\), then \[f^TLf=-(f(1)-f(0))^2,\] which is negative at \(f=(0,1)\). Positivity fails, and the edge form is not an inner product. This example is negative semidefinite; two disjoint edges with weights \(1\) and \(-1\) give an indefinite form, since fields supported on the separate edges have energies of opposite signs.
For unweighted simple graphs, Mathlib's
SimpleGraph.posSemidef_lapMatrix proves positivity of its
Laplacian. That model has no separate weighted edge set; its energy
formula sums both adjacency directions and divides by two. The
edge-once sum above also handles loops and parallel edges, and is proved
directly here.
Lemma. Inverse response for an invertible precision [fdip-001Q]AGENTDRAFTED
- October 20, 2026
Lemma. Inverse response for an invertible precision [fdip-001Q]AGENTDRAFTED
- October 20, 2026
Let \(M\) be a unital module over a commutative unital ring \(R\), with a chosen perfect symmetric pairing \(b\). Let \(L:M\to M\) be self-adjoint, and let \(\mu \in R\). The endomorphism \[Q=L+\mu I_M:M\longrightarrow M\] is self-adjoint. Assume additionally that \(Q\) is an isomorphism, and put \(G=Q^{-1}\). Then \(G^\dagger =G\), and for every source \(j\in M\) the equation \[Qf=j\] has the unique solution \(f=Gj\).
This is a direct consequence of the adjoint and inverse laws and the two-sided inverse convention of [stacks2017stacks, Definition 4.2.4], Tag 0017.
Proof.
- October 20, 2026
Proof.
- October 20, 2026
Linearity of the adjoint and \(I^\dagger =I\) give \(Q^\dagger =L^\dagger +\mu I=Q\). The inverse-adjoint law gives \(G^\dagger =(Q^\dagger )^{-1}=G\). Since \(QG=I\), \(Q(Gj)=j\). Conversely, if \(Qf=j\), then \(GQ=I\) gives \(f=Gj\).
For \(M=\mathcal F_R(V)\) on a finite set with its perfect counting duality, define the point kernel only after this inverse map exists: \[G(v,u)=(G\delta _u)(v).\] The indicator expansion and linearity give \[(Gf)(v)=\sum _{u\in V}G(v,u)f(u).\] Moreover, \[\begin {aligned} G(v,u)&=b(\delta _v,G\delta _u)\\ &=b(G\delta _v,\delta _u)=G(u,v). \end {aligned}\] Thus the symmetric array presents the already defined inverse. On the zero module the unique endomorphism is the identity and is invertible; for an empty carrier the kernel and these sums are empty.
A unit mass coefficient does not ensure invertibility over a ring. Over \(\mathbb Z\), take one unit-weight edge \(0\to 1\), the Laplacian \(L(a,b)=(a-b,b-a)\), and \(\mu =1\). Then \[Q(a,b)=(2a-b,2b-a).\] If \(Q(a,b)=(1,0)\), the second equation gives \(a=2b\), and the first gives \(3b=1\), impossible in \(\mathbb Z\). Thus \(Q\) is not onto, even though the mass and edge weight are units. The real massive Green operator acquires invertibility from positive energy and finite dimension. No positivity, spectrum or probability law is asserted over an arbitrary \(R\).
Eliminating a chosen summand [fdip-0020]AGENTDRAFTED
- October 23, 2026
Eliminating a chosen summand [fdip-0020]AGENTDRAFTED
- October 23, 2026
When some field values can be solved for, which equation remains on the others? A chosen partition gives one splitting of a field module. More generally, a specified split module and an invertible eliminated component determine a retained linear map. Triangular factorization explains its inverse and kernel before any pairing or probability law is chosen.
Perfect symmetric pairings turn this factorization into a congruence when the splitting is orthogonal. Positive real inner products then give the Schur positivity criterion, and cycle elimination makes the retained inverse comparison explicit. The later Gaussian elimination adds the measure and normalization needed to interpret a retained marginal.
Definition. Components of a split endomorphism [fdip-001T]AGENTDRAFTED
- October 23, 2026
Definition. Components of a split endomorphism [fdip-001T]AGENTDRAFTED
- October 23, 2026
To eliminate part of a field, first choose which part is retained. Let \(R\) be a commutative unital ring and \(M,X,Y\) unital \(R\)-modules. A chosen binary splitting of \(M\) consists of ordinary \(R\)-linear maps \[\iota _X:X\to M,\quad \iota _Y:Y\to M,\qquad \pi _X:M\to X,\quad \pi _Y:M\to Y\] satisfying all 5 identities \[\begin {aligned} \pi _X\iota _X&=I_X,&\pi _Y\iota _Y&=I_Y,\\ \pi _X\iota _Y&=0,&\pi _Y\iota _X&=0,\\ \iota _X\pi _X+\iota _Y\pi _Y&=I_M. \end {aligned}\] Products apply the right factor first, as in composition and field multiplication. The maps \((x,y)\mapsto \iota _Xx+\iota _Yy\) and \(z\mapsto (\pi _Xz,\pi _Yz)\) are inverse linear maps by these identities. We consequently write \(M=X\oplus Y\) and \(z=(x,y)\) relative to this chosen identification.
Each summand is included in \(M\) and recovered by its projection. The composite \(\pi _X\iota _X\) is \(I_X\), whereas \(\iota _X\pi _X\) is an endomorphism of \(M\). In the partition realization, these are restriction and extension by zero; the latter composite is the support projection.
For an endomorphism \(Q:M\to M\), its components for the chosen splitting are \[\begin {aligned} A&=\pi _XQ\iota _X:X\to X,&B&=\pi _XQ\iota _Y:Y\to X,\\ E&=\pi _YQ\iota _X:X\to Y,&C&=\pi _YQ\iota _Y:Y\to Y. \end {aligned}\] Inserting \(I_M=\iota _X\pi _X+\iota _Y\pi _Y\) gives \[Q(x,y)=(Ax+By,Ex+Cy).\] If the eliminated component \(C\) is an isomorphism, define the split Schur map, relative to this splitting and pivot, by \[S=A-BC^{-1}E:X\longrightarrow X.\] Changing the splitting or the pivot changes the construction.
The module convention is
[stacks2017stacks, Section 10.10], Tag 0581.
Mathlib's CategoryTheory.Biprod.ofComponents gives
components in a preadditive category with binary biproducts.
Its arguments index source then target; after ordering summands
\((Y,X)\), the arguments corresponding to \(Q\) are \((C,B,E,A)\).
[boyd2004convex, Appendix A.5.5, pp. 650-651] treats the real Schur complement. The source eliminates its first block: exchanging its variables to \((y,x)\) makes its block order \((C,E,B,A)\) and its residual \(A-BC^{-1}E\). The chosen-splitting definition above uses only linear maps; it does not assume a basis, pairing or positivity.
The ring elimination example computes the components and Schur map for a concrete chosen splitting.
Theorem. Triangular factorization of a split map [fdip-001U]AGENTDRAFTED
- October 23, 2026
Theorem. Triangular factorization of a split map [fdip-001U]AGENTDRAFTED
- October 23, 2026
Let \(R\) be a commutative unital ring and \(M=X\oplus Y\) a chosen binary splitting of unital \(R\)-modules. Let \(Q(x,y)=(Ax+By,Ex+Cy)\) have the typed components of this splitting, and assume \(C:Y\to Y\) is an isomorphism. Set \[K=C^{-1}E:X\to Y,\qquad S=A-BC^{-1}E:X\to X.\] Define three endomorphisms of \(M\) by \[\begin {aligned} U(x,y)&=(x+BC^{-1}y,y),\\ D(x,y)&=(Sx,Cy),\\ V(x,y)&=(x,y+Kx). \end {aligned}\] Then \(U,V\) are isomorphisms and, with right-factor-first composition, \[Q=UDV.\]
Proof.
- October 23, 2026
Proof.
- October 23, 2026
The displayed maps are linear since every component is linear. Direct substitution on both sides verifies the inverses \[U^{-1}(x,y)=(x-BC^{-1}y,y),\qquad V^{-1}(x,y)=(x,y-Kx).\] These inverses require no inverse of \(S\). Applying the three factors in order gives \[\begin {aligned} DV(x,y)&=(Sx,Ex+Cy),\\ UDV(x,y)&=(Sx+BC^{-1}(Ex+Cy),Ex+Cy)\\ &=(Ax+By,Ex+Cy)=Q(x,y), \end {aligned}\] where \(S+BC^{-1}E=A\) and \(C^{-1}C=I_Y\) give the last equality.
[boyd2004convex, Appendix C.4.1, pp. 672-673] gives real block-system elimination. The proof above extends it directly to modules. The source uses first-pivot order; swapping to the eliminated summand gives the convention here. No finite rank, projectivity or determinant is used.
Mathlib's CategoryTheory.Biprod.gaussian'
supports elimination in a preadditive category with binary biproducts
and an invertible first component. In the order \((Y,X)\), use
\((C,B,E,A)\) as its component arguments. Its notation \(f\gg g\)
applies \(f\) first, so its residual is \(A-BC^{-1}E\).
For finite coordinate index types,
Matrix.fromBlocks_eq_of_invertible₂₂ gives the corresponding
matrix factorization over a commutative ring; its 4 arguments become
\((A,B,E,C)\). These support the factorization, while the subsequent
inverse and kernel
statements have their own proofs.
Theorem. Inverse components and retained compression [fdip-001V]AGENTDRAFTED
- October 23, 2026
Theorem. Inverse components and retained compression [fdip-001V]AGENTDRAFTED
- October 23, 2026
Over a commutative unital ring \(R\), let \(M=X\oplus Y\) be a chosen splitting, with ordinary linear endomorphism \(Q(x,y)=(Ax+By,Ex+Cy)\). Assume that the eliminated component \(C\) is an isomorphism, and put \(S=A-BC^{-1}E\). Then \(Q\) is an isomorphism if and only if \(S\) is an isomorphism. When these conditions hold, all 4 components of the inverse are \[\begin {aligned} \pi _XQ^{-1}\iota _X&=S^{-1}:X\to X,\\ \pi _XQ^{-1}\iota _Y&=-S^{-1}BC^{-1}:Y\to X,\\ \pi _YQ^{-1}\iota _X&=-C^{-1}ES^{-1}:X\to Y,\\ \pi _YQ^{-1}\iota _Y&=C^{-1}+C^{-1}ES^{-1}BC^{-1}:Y\to Y. \end {aligned}\] In particular, the retained compression of \(Q^{-1}\) is \(S^{-1}\); it is not in general \(A^{-1}\).
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Use \(Q=UDV\) and the explicit inverses of \(U,V\) from triangular factorization, where \(D(x,y)=(Sx,Cy)\). If \(S\) is invertible, then \(D^{-1}(u,v)=(S^{-1}u,C^{-1}v)\). Thus \(Q^{-1}=V^{-1}D^{-1}U^{-1}\) is a two-sided inverse.
Conversely, suppose \(Q\) is invertible. Then \(D=U^{-1}QV^{-1}\) is invertible; write \(J=D^{-1}\) and set \(J_X=\pi _XJ\iota _X:X\to X\). The identities \(\pi _XD=S\pi _X\) and \(D\iota _X=\iota _XS\) imply \[\begin {aligned} SJ_X&=\pi _XDJ\iota _X=\pi _X\iota _X=I_X,\\ J_XS&=\pi _XJD\iota _X=\pi _X\iota _X=I_X. \end {aligned}\] Hence \(J_X\) is a two-sided inverse of \(S\). This implication still uses the assumed invertibility of \(C\).
Applying the three inverse factors to \((u,v)\) gives \[\begin {aligned} x&=S^{-1}u-S^{-1}BC^{-1}v,\\ y&=-C^{-1}ES^{-1}u +(C^{-1}+C^{-1}ES^{-1}BC^{-1})v. \end {aligned}\] Setting one input component to zero and projecting the other gives the 4 stated map identities.
The real symmetric inverse formula is
[boyd2004convex, Appendix A.5.5, p. 650]; its first-pivot
convention is exchanged here. The direct proof uses arbitrary unital
\(R\)-modules and needs no pairing or symmetry.
Mathlib's CategoryTheory.Biprod.isoElim' constructs
the residual isomorphism when both the first component and the whole
biproduct map are isomorphisms. With summands \((Y,X)\) and component
arguments \((C,B,E,A)\), it supports the whole-to-residual direction;
it does not by itself assert the 4 inverse formulas above.
For a self-adjoint precision with a chosen perfect pairing, inverse response supplies its separate response interpretation. The cycle calculation exhibits a retained inverse entry \(2/15\) where \(A^{-1}\) has entry zero. No probability law is needed for the map comparison.
Proposition. Eliminating equations and identifying kernels [fdip-001W]AGENTDRAFTED
- October 23, 2026
Proposition. Eliminating equations and identifying kernels [fdip-001W]AGENTDRAFTED
- October 23, 2026
Let \(R\) be a commutative unital ring and choose \(M=X\oplus Y\) with components \(Q(x,y)=(Ax+By,Ex+Cy)\). Assume \(C:Y\to Y\) is an isomorphism and set \(S=A-BC^{-1}E\). For every \(u\in X,v\in Y\), \[Q(x,y)=(u,v)\] is equivalent to the two equations \[y=C^{-1}(v-Ex),\qquad Sx=u-BC^{-1}v.\] No invertibility of \(S\) is required. In particular, the maps \[\begin {aligned} J_S:\ker S&\longrightarrow \ker Q,& x&\longmapsto (x,-C^{-1}Ex),\\ \pi _X:\ker Q&\longrightarrow \ker S,& (x,y)&\longmapsto x \end {aligned}\] are inverse \(R\)-linear maps. Here each kernel is the submodule of elements sent to zero.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
The second component of \(Q(x,y)=(u,v)\) is \(Ex+Cy=v\); since \(C\) is invertible, it is equivalent to \(y=C^{-1}(v-Ex)\). Substitution in \(Ax+By=u\) gives \[Ax+BC^{-1}(v-Ex)=Sx+BC^{-1}v=u.\] Reversing these steps proves the full equivalence.
For any \(x\in X\), direct substitution gives \[Q(x,-C^{-1}Ex)=(Sx,0).\] Thus \(J_S\) sends \(\ker S\) into \(\ker Q\). If \(Q(x,y)=0\), the proved equivalence gives \(Sx=0\) and \(y=-C^{-1}Ex\). Therefore \(\pi _XJ_Sx=x\) and \(J_S\pi _X(x,y)=(x,y)\) on the stated kernels. Both maps are restrictions of linear maps, so this is a module isomorphism, not merely a bijection of sets.
[boyd2004convex, Appendix C.4.1, pp. 672-673] gives real linear-system elimination. The direct argument above extends it to modules. After exchanging the source variables to \((y,x)\) and the right side to \((v,u)\), its first-pivot equations become the displayed formulas. The kernel correspondence does not assume that the whole system is invertible.
The pivot hypothesis cannot be deduced from invertibility of \(Q\). Over a nonzero ring take \(X=Y=R\) and \(Q(x,y)=(y,x)\). Then \(Q^2=I\), but its component \(C=0:R\to R\) is not an isomorphism. These formulas cannot invert that prescribed pivot.
Zero summands cause no exception. If \(Y=0\), its unique endomorphism is its identity and is invertible; then \(S=A\) and elimination changes nothing. If \(X=0\), \(S\) is the unique invertible endomorphism of zero and \(Q=C\). Over the zero ring every unital module is zero, because \(x=1x=0x=0\); all statements remain valid.
Proposition. Elimination with orthogonal perfect pairings [fdip-001X]AGENTDRAFTED
- October 23, 2026
Proposition. Elimination with orthogonal perfect pairings [fdip-001X]AGENTDRAFTED
- October 23, 2026
Let \(X,Y\) be unital modules over a commutative unital ring \(R\), with chosen perfect symmetric pairings \(b_X,b_Y\). On the chosen sum \(M=X\oplus Y\), choose the orthogonal sum form \[b_M((x,y),(x',y'))=b_X(x,x')+b_Y(y,y').\] It is perfect and symmetric, and its injection/projection adjoints are \[\iota _X^\dagger =\pi _X,\quad \pi _X^\dagger =\iota _X,\qquad \iota _Y^\dagger =\pi _Y,\quad \pi _Y^\dagger =\iota _Y.\] Suppose \(Q:M\to M\) is self-adjoint, with components \(A,B,E,C\) and invertible \(C\). Then \[A^\dagger =A,\quad C^\dagger =C,\quad E=B^\dagger ,\qquad S^\dagger =S\quad \text {for }S=A-BC^{-1}E.\] For the triangular factors, \[V^\dagger =U,\qquad Q=V^\dagger DV,\qquad D(x,y)=(Sx,Cy).\] Consequently, with \(K=C^{-1}E\), \[\begin {aligned} b_M((x,y),Q(x,y)) &=b_X(x,Sx)\\ &\quad +b_Y(y+Kx,C(y+Kx)). \end {aligned}\]
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Bilinearity and symmetry of \(b_M\) follow termwise. For a linear functional \(\ell :M\to R\), represent \(\ell \iota _X\) and \(\ell \iota _Y\) uniquely by \(x_\ell \in X,y_\ell \in Y\) using the two perfect pairings. Then for every \((x,y)\), \[\ell (x,y)=\ell \iota _X(x)+\ell \iota _Y(y) =b_X(x,x_\ell )+b_Y(y,y_\ell ).\] This gives a representative \((x_\ell ,y_\ell )\). Uniqueness follows by testing \((x,0)\) and \((0,y)\) separately. The representative depends linearly on \(\ell \), since the two inverse duality maps are linear. Thus the currying map of \(b_M\) is a linear isomorphism.
For example, \(b_M(\iota _Xx,(u,v))=b_X(x,u)=b_X(x,\pi _X(u,v))\). Adjoint uniqueness and involution give the two \(X\) identities, and the same calculation gives those for \(Y\). Adjointing the definitions of the 4 components and using \(Q^\dagger =Q\) gives \(A^\dagger =A\), \(C^\dagger =C\) and \(B^\dagger =E\). The inverse-adjoint law then gives \((C^{-1})^\dagger =C^{-1}\) and \[K^\dagger =(C^{-1}E)^\dagger =BC^{-1},\qquad (BC^{-1}E)^\dagger =BC^{-1}E.\] The latter identity proves \(S^\dagger =S\).
For \(z=(x,y)\) and \(w=(u,v)\), \[\begin {aligned} b_M(Vz,w) &=b_X(x,u)+b_Y(y+Kx,v)\\ &=b_X(x,u+K^\dagger v)+b_Y(y,v)\\ &=b_M(z,Uw). \end {aligned}\] Uniqueness gives \(V^\dagger =U\); factorization yields \(Q=V^\dagger DV\). Finally \(b_M(z,Qz)=b_M(Vz,DVz)\), and expanding the orthogonal sum form gives the stated identity.
This is a direct deduction from chosen dualities and triangular factorization. The real symmetric completion in [boyd2004convex, Appendix A.5.5, p. 650] is its real coordinate specialization. The chosen orthogonal sum is essential: an arbitrary perfect form on \(M\) need not have these injection/projection adjoints. No division by two or recovery of bilinear data from diagonal values is used; the identity remains valid in characteristic two.
TauCeti's LinearMap.BilinForm.prod gives the
orthogonal product form, and
LinearMap.BilinForm.nondegenerate_prod_iff identifies
its radical nondegeneracy. The functional-splitting proof above also
proves the surjectivity required for perfection. These declarations
alone do not assert the paired-congruence result.
Proposition. Positive definiteness under elimination [fdip-001Y]AGENTDRAFTED
- October 23, 2026
Proposition. Positive definiteness under elimination [fdip-001Y]AGENTDRAFTED
- October 23, 2026
Let \(X,Y\) be finite-dimensional real vector spaces with positive definite inner products \(b_X,b_Y\). Give \(M=X\oplus Y\) their orthogonal sum, and let \(Q:M\to M\) be self-adjoint, with components \(A,B,E,C\). For a self-adjoint map \(T\) on any of these spaces, write \(T>0\) when \(b(z,Tz)>0\) for every nonzero \(z\).
If \(Q>0\), then \(C\) is positive definite and invertible, and \(S=A-BC^{-1}E\) is positive definite and invertible. Conversely, if \(C\) is invertible, then \[Q>0\quad \Longleftrightarrow \quad C>0\ \text {and}\ S>0.\]
[boyd2004convex, Appendix A.5.5, p. 650] gives the positive-definite Schur criterion. Here the eliminated summand is placed second.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
The currying map of each inner product is injective. Indeed, if \(b(z,u)=0\) for every \(z\), take \(z=u\); positive definiteness gives \(u=0\). Finite dimension makes this map onto the dual, which has the same dimension. Thus these forms are chosen perfect pairings, and the paired-congruence identity applies whenever \(C\) is invertible.
Assume \(Q>0\). For \(y\ne 0\), \(\iota _Yy\ne 0\) and \[b_Y(y,Cy)=b_M(\iota _Yy,Q\iota _Yy)>0.\] Hence \(C>0\). If \(Cy=0\), positivity forces \(y=0\); finite dimension then turns injectivity into surjectivity, so \(C\) is invertible. For \(x\ne 0\), the vector \((x,-C^{-1}Ex)\) is nonzero and congruence gives \[b_X(x,Sx) =b_M((x,-C^{-1}Ex),Q(x,-C^{-1}Ex))>0.\] Thus \(S>0\), and the same injectivity and finite-dimension argument makes \(S\) invertible.
Conversely, suppose \(C>0\) and \(S>0\). For any nonzero \(z=(x,y)\), the invertible map \(V(x,y)=(x,y+C^{-1}Ex)\) has \(Vz\ne 0\). At least one of its two components is nonzero. The corresponding term of \[b_M(z,Qz)=b_X(x,Sx)+b_Y(y+C^{-1}Ex,C(y+C^{-1}Ex))\] is strictly positive, and the other is nonnegative. Hence \(Q>0\). If a summand is zero, its positivity assertion is vacuous and its unique endomorphism is invertible, so the same argument includes it.
This uses finite-dimensional real positivity in addition to the ring-level factorization. It explains the positivity assumption in real effective precision. It does not evaluate an integral or determine a normalization factor; those require the separately specified real measure and Gaussian law.
Example. Eliminating alternate vertices of a ring-valued cycle [fdip-001Z]AGENTDRAFTED
- October 23, 2026
Example. Eliminating alternate vertices of a ring-valued cycle [fdip-001Z]AGENTDRAFTED
- October 23, 2026
Use the four-cycle endpoints \(s(e_i)=i\), \(h(e_i)=i+1\) on \(\mathbb Z/4\mathbb Z\), but now let \(R\) be any commutative unital ring and take \(t,\mu \in R\). Give successive edges weights \((1,t,1,t)\). On the finite function modules with their counting pairings, set \[Q=d^\dagger Wd+\mu I,\qquad s=1+t+\mu .\] Here \(d\) is incidence and \(W\) multiplies each edge field by its weight. This extends the positive-real weight choice in Example [fdip-0003]; no weight is assumed positive or invertible.
First compute from endpoints. The difference is \((df)(e_i)=f(i+1)-f(i)\). Grouping the incoming and outgoing edge terms gives \[(d^\dagger Wdf)(i) =w(e_{i-1})(f(i)-f(i-1))+w(e_i)(f(i)-f(i+1)).\] Adding \(\mu f(i)\) yields \[\begin {aligned} (Qf)(0)&=sf(0)-f(1)-tf(3),\\ (Qf)(1)&=sf(1)-f(0)-tf(2),\\ (Qf)(2)&=sf(2)-tf(1)-f(3),\\ (Qf)(3)&=sf(3)-tf(0)-f(2). \end {aligned}\]
Choose the additional partition \(V_0=\{0,2\}\), \(V_1=\{1,3\}\), and put \(X=\mathcal F_R(V_0)\), \(Y=\mathcal F_R(V_1)\). Restriction and extension by zero give the chosen splitting. The resulting component maps are \[\begin {aligned} A&=sI_X,&C&=sI_Y,\\ (Ex)(1)&=-x(0)-tx(2),&(Ex)(3)&=-tx(0)-x(2),\\ (By)(0)&=-y(1)-ty(3),&(By)(2)&=-ty(1)-y(3). \end {aligned}\] The pivot \(C\) is invertible exactly when \(s\) is a unit. A unit gives \(C^{-1}=s^{-1}I_Y\). Conversely, if \(CJ=I_Y\), evaluation of \(CJ\delta _1=\delta _1\) at vertex \(1\) gives \(s(J\delta _1)(1)=1\); commutativity makes this a two-sided inverse of \(s\). In the zero ring \(0=1\) is a unit, consistently with this argument.
Assume this unit condition. Applying \(B\) to \(Ex\) gives \[\begin {aligned} (BEx)(0)&=(1+t^2)x(0)+2tx(2),\\ (BEx)(2)&=2tx(0)+(1+t^2)x(2). \end {aligned}\] Consequently the split Schur map is \[\begin {aligned} (Sx)(0)&=[s-s^{-1}(1+t^2)]x(0)-2ts^{-1}x(2),\\ (Sx)(2)&=[s-s^{-1}(1+t^2)]x(2)-2ts^{-1}x(0). \end {aligned}\] Here \(2=1+1\); neither \(2\), \(t\), \(\mu \) nor \(S\) is asserted to be invertible. In coordinates ordered \((0,2)\), the same map is \[[S]=\begin {pmatrix} s-s^{-1}(1+t^2)&-2ts^{-1}\\ -2ts^{-1}&s-s^{-1}(1+t^2) \end {pmatrix}.\] This array presents the map just computed from endpoints.
The half-turn exchanges \(0\leftrightarrow 2\) and \(1\leftrightarrow 3\). Let \(r_X,r_Y\) exchange the corresponding field values. The component formulas give \(Ar_X=r_XA\), \(Cr_Y=r_YC\), \(Er_X=r_YE\) and \(Br_Y=r_XB\); hence \(Sr_X=r_XS\). A one-step shift exchanges the two parts and fails to preserve the alternating weights when \(t\ne 1\). No retained partition is implicit in general incidence data.
Now specialize to \(R=\mathbb R\), \(t>0\), \(\mu =m^2>0\). The weighted energy identity gives, for \(f\ne 0\), \[b(f,Qf)=\sum _e w(e)(df(e))^2+m^2\sum _v f(v)^2>0.\] Thus \(Q\) is positive definite and invertible, and the positive-real criterion gives \(S>0\). At \(t=m=1\), \(s=3\) and \[[S]=\frac 13\begin {pmatrix}7&-2\\-2&7\end {pmatrix}.\] To solve \(Sx=\delta _2\), solve \(7x(0)-2x(2)=0\) and \(-2x(0)+7x(2)=3\). These give \(x(2)=7/15\) and \(x(0)=2/15\). Therefore \[(\pi _XQ^{-1}\iota _X\delta _2)(0) =(S^{-1}\delta _2)(0)=\frac {2}{15}.\] By contrast, fixing the eliminated field to zero leaves the retained map \(A=3I_X\), and \((A^{-1}\delta _2)(0)=0\). These are different map operations.
At real \(\mu =0,t>0\), the pivot \(C=(1+t)I_Y\) is still invertible. But \(s-s^{-1}(1+t^2)=2t/(1+t)\), so the nonzero constant retained field satisfies \(S1=0\). The kernel correspondence then recovers the constant full field in \(\ker Q\), since \(-C^{-1}E1=1\). An invertible pivot does not imply an invertible full precision.
[spielman2009effective, Section 2.1, pp. 4-5] gives the incidence sign convention for positive real weights. The arbitrary-ring identities use the direct counting construction of Definition [fdip-0007].
[boyd2004convex, Appendix C.4.1, pp. 672-673] gives the real elimination convention. All coefficients and inverse entries here were computed from the specified endpoints and weights. They recover the algebraic values in real alternate-vertex elimination; the covariance and marginal-law interpretation there additionally uses the Gaussian measure. No massless Gaussian formula follows by substituting \(\mu =0\) into a massive normalization.
How do we describe fields other than a distinguished solution? In the finite real specialization with counting inner product and symmetric positive-definite precision \(Q\), a source \(j\) singles out \(f=Q^{-1}j\), the unique solution of \(Qf=j\). Completing the square also makes it the minimizer of \(f^TQf-2j^Tf\). This extra positivity does not belong to the general ring-level elimination above. Even in this case, a solution does not specify probabilities for other fields. Statistical fluctuations require a law and the expected values of observables. The next chapter starts with a finite law; reference measure and Gaussian integrability later make that question precise for real-valued fields.
States and pullback of observables [fdip-002B]AGENTDRAFTED
- October 23, 2026
States and pullback of observables [fdip-002B]AGENTDRAFTED
- October 23, 2026
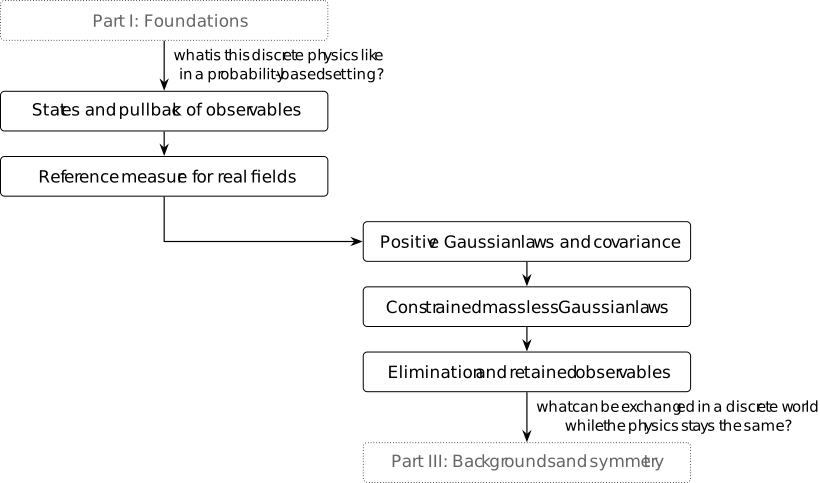
How can a model describe many possible fields and average what we observe? A law on a finite set of configurations assigns probability weights to those fields and averages their observables. The 16 binary fields on the four-cycle give a concrete example: summing weights over configurations with the same retained values produces the retained law. These probability weights are chosen independently of the edge energies. Real probability weights on binary fields are distinct from real-valued field coordinates. Observable algebras and normalized functionals express this operation without assuming a finite configuration set.
A supplied algebra map pulls a functional back by precomposition. Over the reals or complexes, positivity and the involution determine which functionals are states; the real dual-number example explains why the hypotheses matter. Coordinate restriction then pulls polynomial observables back. For real fields with infinitely many configurations, reference measure and Gaussian integrability give the corresponding expectations.
Definition. Normalized linear functionals [fdip-0021]AGENTDRAFTED
- October 23, 2026
Definition. Normalized linear functionals [fdip-0021]AGENTDRAFTED
- October 23, 2026
Let \(R\) be a commutative unital ring, allowing \(1=0\), and let \(A\) be a unital associative algebra over \(R\). Its scalar map is \(\eta :R\to A\), \(r\mapsto r1_A\), with central image. A normalized linear functional is an ordinary \(R\)-linear map \(\omega :A\to R\) satisfying \(\omega (1_A)=1_R\). Thus \(\omega (ra+sb)=r\omega (a)+s\omega (b)\); the coefficient map for linearity is \(\mathrm {id}_R\), not a nontrivial semilinear twist. This is a member of the dual module, with an additional normalization condition.
Normalization is equivalent to \(\omega \circ \eta =\mathrm {id}_R\). In particular, a normalized functional can exist only if \(\eta \) is injective. This necessary condition alone is not a claim of existence.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
If \(\omega (1_A)=1_R\), linearity gives \(\omega (\eta (r))=\omega (r1_A)=r\omega (1_A)=r\). Conversely, evaluating \(\omega \eta =\mathrm {id}_R\) at \(1_R\) gives \(\omega (1_A)=1_R\). A map with a left inverse is injective.
For example, the scalar map \(\mathbb Z\to \mathbb Z/2\mathbb Z\) is not injective, so this algebra admits no normalized \(\mathbb Z\)-linear functional. If \(A\) is the zero algebra, normalization is possible exactly when \(R\) is the zero ring. If \(R\) is the zero ring, every unital \(R\)-module is zero, since \(a=1_Ra=0_Ra=0\); its unique functional is normalized.
The algebra conventions are those of
[stacks2017stacks, Section 22.2], Tag 09JF and
[jadczyk2019notes, Definition 1.6, p. 4].
Mathlib's Module.Dual supplies the ordinary linear dual;
normalization and the scalar left-inverse criterion are the additional
conditions proved here. No order, involution or topology is part of this definition.
Example. Observables on a finite configuration set [fdip-0022]AGENTDRAFTED
- October 23, 2026
Example. Observables on a finite configuration set [fdip-0022]AGENTDRAFTED
- October 23, 2026
Let \(V\) be a finite vertex set and \(S\) a finite set of possible values. A configuration is a function \(\sigma :V\to S\); the configuration set is \(\Omega =S^V\). The set \(\Omega \) is distinct from the vertex set \(V\): an observable takes a whole configuration as its input. For a commutative unital ring \(R\), set \[A_\Omega =\operatorname {Map}(\Omega ,R).\] This is the pointwise function algebra: \((f+g)(\sigma )=f(\sigma )+g(\sigma )\), \((fg)(\sigma )=f(\sigma )g(\sigma )\) and \((rf)(\sigma )=rf(\sigma )\), with unit the constant function \(1_R\).
For each \(\sigma \in \Omega \), evaluation \(\operatorname {ev}_\sigma (f)=f(\sigma )\) is a unital \(R\)-algebra map and a normalized linear functional. The scalar map sends \(r\) to the constant function \(r\). The indicator \(\delta _\sigma \) is \(1_R\) at \(\sigma \) and \(0_R\) elsewhere. These are the same indicators used in counting duality for finite functions, now indexed by configurations.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Each algebra law follows by evaluating at every configuration and using the corresponding law in \(R\). Evaluation preserves addition, scalar multiplication, products and the unit by the displayed definitions. The indicators satisfy \[\delta _\sigma ^2=\delta _\sigma ,\qquad \delta _\sigma \delta _\tau =0\ (\sigma \ne \tau ),\qquad \sum _{\sigma \in \Omega }\delta _\sigma =1.\] These equalities hold pointwise, including when \(R\) is the zero ring.
If \(V=\varnothing \), then \(S^V\) contains the unique empty function, even when \(S=\varnothing \). If \(S=\varnothing \) and \(V\ne \varnothing \), then \(\Omega =\varnothing \); its function algebra is the zero algebra. There is then no evaluation at a configuration.
The underlying unital algebra convention is
[stacks2017stacks, Section 22.2], Tag 09JF.
Mathlib's Pi.algebra, Pi.evalAlgHom and
Pi.constAlgHom provide the pointwise algebra, evaluation and
constant algebra maps. The configuration interpretation and the empty-set
cases above are direct consequences of these definitions.
Proposition. Finite functionals and their weights [fdip-0023]AGENTDRAFTED
- October 23, 2026
Proposition. Finite functionals and their weights [fdip-0023]AGENTDRAFTED
- October 23, 2026
For a finite set \(\Omega \) and commutative unital ring \(R\), every \(R\)-linear functional on the function algebra has a unique weight function \(p:\Omega \to R\), given by \[\omega (f)=\sum _{x\in \Omega }p(x)f(x),\qquad p(x)=\omega (\delta _x).\] Conversely, every such weight function defines an \(R\)-linear functional. It is normalized exactly when \(\sum _xp(x)=1_R\).
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Pointwise evaluation gives \(f=\sum _x f(x)\delta _x\). Linearity therefore gives the stated formula, using commutativity of \(R\) to write the coefficients in either order. Conversely, distributivity of the finite sum proves linearity of the formula. Evaluating it on \(\delta _y\) recovers \(p(y)\), proving uniqueness in both directions. Evaluating at \(1=\sum _x\delta _x\) proves the normalization criterion.
When \(\Omega =\varnothing \), the sole functional is the zero map from the zero algebra and its total weight is \(0_R\); it is normalized exactly when \(R\) is the zero ring. When \(\Omega \ne \varnothing \), a chosen evaluation is normalized over every \(R\). Uniform weights \(p(x)=c\) on a set of size \(n>0\) are normalized exactly when \((n1_R)c=1_R\). Such normalized uniform weights exist exactly when \(n1_R\) is a unit, and then the unique coefficient is \(c=(n1_R)^{-1}\). Thus failure of uniform normalization does not imply failure of all normalized functionals.
More generally, for raw weights \(w(x)\) with total \(Z=\sum _xw(x)\), a common rescaling \(p(x)=cw(x)\) is normalized exactly when \(cZ=1_R\). This is possible exactly when \(Z\) is a unit, and then \(c=Z^{-1}\) is unique. No division by a nonunit is defined by this formula. In the zero ring the sole element is a unit, so the same criterion applies. For real nonnegative weights, \(Z>0\) exactly when at least one weight is positive; all-zero weights cannot be normalized by rescaling.
This is the indicator-basis argument of finite function duality, with the unital algebra convention of [stacks2017stacks, Section 22.2], Tag 09JF. For real nonnegative normalized weights it gives the finite expectation. No positivity or division is needed for the ring-valued classification.
Definition. Real and complex algebraic states [fdip-0024]AGENTDRAFTED
- October 23, 2026
Definition. Real and complex algebraic states [fdip-0024]AGENTDRAFTED
- October 23, 2026
Let \(K=\mathbb R\) or \(K=\mathbb C\), with conjugation the identity in the real case. Let \(A\) be a unital associative \(K\)-algebra equipped with an additive operation \(a\mapsto a^*\) satisfying \[\begin {aligned} (\lambda a)^*&=\overline \lambda a^*,& (ab)^*&=b^*a^*,\\ (a^*)^*&=a,&1^*&=1. \end {aligned}\] There is no graded sign in the product law. A \(K\)-linear functional \(\omega :A\to K\) is Hermitian positive when \[\omega (a^*)=\overline {\omega (a)},\qquad \omega (a^*a)\in \mathbb R_{\geq 0}\quad (a\in A).\] A real algebraic state, respectively a complex algebraic state, is such a functional that is also normalized. The scalar field and involution are part of the assertion.
Over \(\mathbb C\), nonnegativity on all \(a^*a\) already implies Hermiticity, without assuming normalization. Over \(\mathbb R\), Hermiticity is a separate requirement, as the real dual-number example shows.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Suppose \(K=\mathbb C\) and \(\omega (a^*a)\in \mathbb R_{\geq 0}\) for every \(a\). For \(h=h^*\), expansion and linearity give \[\begin {aligned} 4\omega (h)={}&\omega ((1+h)^*(1+h))\\ &-\omega ((1-h)^*(1-h))\in \mathbb R. \end {aligned}\] For arbitrary \(a\), put \(h=(a+a^*)/2\) and \(k=(a-a^*)/(2i)\). Conjugate scalar compatibility gives \(h=h^*\), \(k=k^*\), \(a=h+ik\) and \(a^*=h-ik\). The preceding calculation makes \(\omega (h)\) and \(\omega (k)\) real. Hence \(\omega (a^*)=\omega (h)-i\omega (k)=\overline {\omega (a)}\).
For these conventions, see [waldmann2004states, Section 3.1, p. 9; Definition 3.7 and Definition 3.9 with Remark 3.10(iv), p. 11]. Waldmann works over a complexification of an ordered ring. Here the coefficients are the ordinary fields \(\mathbb R\) and \(\mathbb C\); the real Hermiticity requirement is explicit. On p. 9, Definition 3.1 prints \(R=-P\sqcup \{0\}\sqcup R\); the intended final \(P\), rather than the printed \(R\), is a mathematical emendation, not a verbatim transcription.
The ordinary linear involution is not a substitute for conjugate scalar compatibility over \(\mathbb C\). With a complex-linear unital involution, \((i1)^*(i1)=-1\); a normalized functional takes this to \(-1\), contradicting square positivity. The earlier chosen bilinear adjoints likewise do not supply this Hermitian structure. No norm, continuity or operator representation is assumed.
Example. Square positivity need not imply real Hermiticity [fdip-0025]AGENTDRAFTED
- October 23, 2026
Example. Square positivity need not imply real Hermiticity [fdip-0025]AGENTDRAFTED
- October 23, 2026
In the real algebra \(A=\mathbb R[\varepsilon ]/(\varepsilon ^2)\), each element is uniquely \(x+y\varepsilon \). Define \((x+y\varepsilon )^*=x-y\varepsilon \). For any fixed real \(c\ne 0\), let \[\omega _c(x+y\varepsilon )=x+cy.\] Then \(\omega _c\) is normalized and nonnegative on every \(a^*a\), but is not a real algebraic state, because it is not Hermitian.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
The operation is real linear, fixes the unit and squares to the identity. Multiplication gives \((x+y\varepsilon )(u+v\varepsilon )=xu+(xv+yu)\varepsilon \); applying star negates the second coefficient, as does multiplying the starred factors. Since the algebra is commutative, this is also the required order-reversing product law. For \(a=x+y\varepsilon \), \(a^*a=(x-y\varepsilon )(x+y\varepsilon )=x^2\). Thus \(\omega _c(a^*a)=x^2\geq 0\), and \(\omega _c(1)=1\). But \(\omega _c(\varepsilon ^*)=-c\ne c=\omega _c(\varepsilon )\).
This direct calculation distinguishes square positivity from the extra real Hermiticity condition. Square positivity is defined in [waldmann2004states, Definition 3.9, p. 11]. It is separate from the characteristic-two group-algebra example: the present algebra and functional are over \(\mathbb R\).
Proposition. Finite states are probability weights [fdip-0026]AGENTDRAFTED
- October 23, 2026
Proposition. Finite states are probability weights [fdip-0026]AGENTDRAFTED
- October 23, 2026
Let \(\Omega \) be finite, \(K=\mathbb R\) or \(\mathbb C\), and give \(A_\Omega =\operatorname {Map}(\Omega ,K)\) the pointwise involution \(f^*(x)=\overline {f(x)}\). The weight functional \(\omega _p(f)=\sum _xp(x)f(x)\) is a real or complex algebraic state exactly when every \(p(x)\) is real and nonnegative and \(\sum _xp(x)=1\).
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Pointwise conjugation is additive, conjugates scalars, fixes the unit and is involutive. It reverses products because \(K\) is commutative. For necessity, \(\delta _x^*\delta _x=\delta _x\), so square positivity gives \(p(x)=\omega _p(\delta _x)\in \mathbb R_{\geq 0}\). Normalization gives the sum condition. Conversely, real weights imply \(\omega _p(f^*)=\sum _xp(x)\overline {f(x)}=\overline {\omega _p(f)}\). Furthermore \[\omega _p(f^*f)=\sum _xp(x)|f(x)|^2\geq 0,\] and \(\omega _p(1)=\sum _xp(x)=1\). For a real pointwise nonnegative function, each summand \(p(x)f(x)\) is also nonnegative, so its expectation is nonnegative.
There is no state on the empty configuration set over \(\mathbb R\) or \(\mathbb C\), because the empty sum is zero. On two points, the weights \(p(0)=p(1)=1/2\) give a state that is not multiplicative: \(\omega _p(\delta _0\delta _1)=0\), whereas \(\omega _p(\delta _0)\omega _p(\delta _1)=1/4\). A state is not required to be an algebra homomorphism.
The positive-functional convention is [waldmann2004states, Definition 3.9, p. 11]; the indicator calculation above identifies it with finite probability and expectation on this particular algebra. It does not identify positivity cones on arbitrary star algebras; the distinctions on [waldmann2004states, p. 12] remain separate.
Proposition. Pulling a functional back along a supplied algebra map [fdip-0027]AGENTDRAFTED
- October 23, 2026
Proposition. Pulling a functional back along a supplied algebra map [fdip-0027]AGENTDRAFTED
- October 23, 2026
Let \(R\) be a commutative unital ring, \(A,B\) unital associative \(R\)-algebras, and let \(\iota :B\to A\) be a supplied unital algebra homomorphism. Precomposition defines an \(R\)-linear map in the opposite direction on ordinary duals: \[\begin {aligned} \iota ^\flat :\operatorname {Hom}_R(A,R)&\longrightarrow \operatorname {Hom}_R(B,R),\\ \omega &\longmapsto \omega \circ \iota . \end {aligned}\] It sends normalized functionals to normalized functionals. For another unital associative \(R\)-algebra \(C\) and a unital \(R\)-algebra homomorphism \(\kappa :C\to B\), \[(\iota \circ \kappa )^\flat =\kappa ^\flat \circ \iota ^\flat , \qquad (\mathrm {id}_A)^\flat =\mathrm {id}.\] When \(\iota \) is inclusion this is literal restriction; for an injective map it becomes restriction after identifying \(B\) with its image. No injectivity is needed for precomposition itself. A partition of a set by itself does not supply an algebra map between arbitrary algebras.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
For \(b,c\in B\) and \(r,s\in R\), linearity of \(\iota \) and \(\omega \) gives \((\omega \iota )(rb+sc)=r(\omega \iota )(b)+s(\omega \iota )(c)\). Pointwise operations on the dual also give \((r\omega +s\nu )\iota =r(\omega \iota )+s(\nu \iota )\). Since \(\iota (1_B)=1_A\), normalization follows from \((\omega \iota )(1_B)=\omega (1_A)=1_R\). For every \(c\in C\), both sides of the composition identity take \(\omega \) to \(\omega (\iota (\kappa (c)))\); the identity law is immediate by evaluation.
Linearity and preservation of the unit suffice for the normalization calculation; multiplication preservation additionally respects observable products. Without unitality, the zero multiplicative linear map between nonzero real algebras pulls every normalized functional back to zero.
Over \(K=\mathbb R\) or \(\mathbb C\), suppose both algebras carry the star laws in the state definition, and suppose additionally \(\iota (b^*)=\iota (b)^*\). Then \(\iota ^\flat \) sends algebraic states to algebraic states. For composition in this setting, let \(C\) also be a unital associative \(K\)-algebra with these star laws, and let \(\kappa :C\to B\) be a unital \(K\)-algebra homomorphism preserving star.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
For a state \(\omega \), \((\omega \iota )(b^*)=\omega (\iota (b)^*)=\overline {\omega (\iota (b))}\). Multiplication and star compatibility give \[(\omega \iota )(b^*b)=\omega (\iota (b)^*\iota (b))\geq 0.\] Normalization holds. Identities preserve star, and \((\iota \kappa )(c^*)=\iota (\kappa (c)^*)=(\iota \kappa (c))^*\), so composition preserves the same hypotheses.
Star compatibility cannot be omitted. Give \(\mathbb C[z]\) the involution conjugating coefficients and fixing \(z\); give \(\mathbb C\) ordinary conjugation. Evaluation at \(z=i\) is a unital complex algebra map. The identity functional on \(\mathbb C\) is a state, but its pullback takes \(z^*z=z^2\) to \(-1\), so is not positive.
The dual-map construction is supported by Mathlib's
LinearMap.dualMap, LinearMap.dualMap_apply,
LinearMap.dualMap_id and LinearMap.dualMap_comp_dualMap;
these do not require finite dimension. The star-preserving map structures
StarAlgHom and StarAlgHom.comp concern supplied star
operations; the genuine star laws above remain explicit hypotheses.
For the algebra and positivity conventions see
[stacks2017stacks, Section 22.2], Tag 09JF and
[waldmann2004states, Definitions 3.7 and 3.9, p. 11].
The normalization and positivity assertions here are proved directly.
Proposition. Finite-map pullback and fiber weights [fdip-0028]AGENTDRAFTED
- October 23, 2026
Proposition. Finite-map pullback and fiber weights [fdip-0028]AGENTDRAFTED
- October 23, 2026
Let \(\rho :\Omega \to \Lambda \) be any map of finite sets and let \(R\) be a commutative unital ring. On the function algebras, \[\begin {aligned} \rho ^*:A_\Lambda &\longrightarrow A_\Omega ,& f&\longmapsto f\circ \rho \end {aligned}\] is a unital \(R\)-algebra map. Over \(\mathbb R\) or \(\mathbb C\) it preserves pointwise conjugation. For \(\tau :\Lambda \to \Gamma \), \((\tau \circ \rho )^*=\rho ^*\circ \tau ^*\), and the identity set map induces the identity algebra map.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
At \(x\in \Omega \), pullback of \(rf+sg\), \(fg\), and \(1\) has value \(rf(\rho (x))+sg(\rho (x))\), \(f(\rho (x))g(\rho (x))\), and \(1_R\), respectively. Pullback commutes with conjugation by the same evaluation. Both composite pullbacks evaluate \(f\) at \(\tau (\rho (x))\); the identity case evaluates \(f\) at \(x\). These pointwise arguments also apply to empty domains and the zero ring.
The image of \(\rho ^*\) consists exactly of functions constant on each fiber of \(\rho \). If \(\rho \) is surjective, \(\rho ^*\) is injective. Conversely, injectivity of \(\rho ^*\) forces surjectivity of \(\rho \) provided \(R\) is nonzero.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
A pullback takes equal values at \(x,x'\) whenever \(\rho (x)=\rho (x')\). Conversely, for fiber-constant \(g\), define \(f(y)\) to be the common value on the fiber when that fiber is nonempty, and \(0_R\) when it is empty. The value is independent of the chosen representative, and \(g=f\rho \). If \(\rho \) is surjective, equality of two pullbacks determines their value at every \(y\), proving injectivity. If \(y\) is missed, \(\delta _y\) pulls back to zero; for nonzero \(R\) this indicator is nonzero, so pullback is not injective. Over the zero ring, all these algebras are singletons and every pullback is injective, including pullback along a nonsurjective set map.
For the weight functional determined by \(p\), its pullback as a functional along \(\rho ^*\) has weights \[q(y)=\sum _{\rho (x)=y}p(x).\] Thus normalized weights stay normalized; real nonnegative weights stay nonnegative. Empty fibers have weight zero.
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Regroup the finite sum: \[\begin {aligned} (\omega _p\circ \rho ^*)(f) &=\sum _{x\in \Omega }p(x)f(\rho (x))\\ &=\sum _{y\in \Lambda }\left (\sum _{\rho (x)=y}p(x)\right )f(y). \end {aligned}\] The fibers partition \(\Omega \), so \(\sum _yq(y)=\sum _xp(x)\). Nonnegative summands give nonnegative fiber sums. For successive maps, \[\sum _{\tau (y)=z}\sum _{\rho (x)=y}p(x) =\sum _{\tau (\rho (x))=z}p(x),\] which proves compatibility of the fiber formula with composition.
For real nonnegative weights of total one, this is
pushforward of finite probabilities, or a marginal law
when \(\rho \) forgets coordinates. It uses no division by
fiber mass, even when that mass is zero; it is not a conditional
expectation. The pointwise algebra construction uses
[stacks2017stacks, Section 22.2], Tag 09JF.
Mathlib's AlgHom.pi constructs the family of evaluation maps
\(f\mapsto f(\rho (x))\). Composition here changes the function's domain,
not its coefficient ring.
Over arbitrary rings, not every unital algebra map between function algebras is induced by a set map. For \(R=\mathbb Z/6\mathbb Z\), define \(h:R^2\to R\) by \(h(a,b)=3a+4b\). It is \(R\)-linear and unital since \(3+4=1\). The identities \(3^2=3\), \(4^2=4\), and \(3\cdot 4=0\) show \(h(a,b)h(c,d)=3ac+4bd=h(ac,bd)\), so it is multiplicative. But \(h(1,0)=3\), whereas either coordinate evaluation gives \(0\) or \(1\). Thus this map is not the pullback of a map from a singleton to two points.
Example. A nonuniform law on sixteen cycle configurations [fdip-0029]AGENTDRAFTED
- October 23, 2026
Example. A nonuniform law on sixteen cycle configurations [fdip-0029]AGENTDRAFTED
- October 23, 2026
Use the 4 vertices \(V=\{0,1,2,3\}\) of the alternating cycle, the alphabet \(S=\{0,1\}\), and retained vertices \(J=\{0,2\}\). There are 16 configurations \(\Omega =S^V\) and 4 retained configurations \(\Lambda =S^J\). The map \(\rho (\sigma )=\sigma |_J\) is surjective: assign zero at vertices \(1,3\) to extend any retained configuration. Each fiber has 4 elements. The pullback identifies retained observables with those depending only on the values at vertices \(0,2\).
Choose the following real weights, independently of the edge energies: \[p(\sigma )=\begin {cases} 1/12,&\sigma _0=\sigma _2,\\ 1/24,&\sigma _0\ne \sigma _2. \end {cases}\] There are 8 configurations of each kind, so \(\sum _\sigma p(\sigma )=8/12+8/24=1\). By the finite-state criterion, this defines a real algebraic state. Summing the 4 weights in each fiber gives \[q(0,0)=q(1,1)=1/3,\qquad q(0,1)=q(1,0)=1/6.\] For \(F(\eta )=\eta _0\eta _2\), only \(\eta =(1,1)\) contributes, and hence \[\omega _q(F)=1/3=4\cdot (1/12)=\omega _p(F\circ \rho ).\] This is an explicit instance of the finite fiber-sum identity.
The law here is a chosen finite probability distribution. It is not obtained from the cycle's edge weights or its precision matrix, and the carrier \(S^V\) is distinct from the real configuration space \(\mathbb R^V\) used by the Gaussian law. The algebra convention remains [stacks2017stacks, Section 22.2], Tag 09JF; the positivity convention is [waldmann2004states, Definition 3.9, p. 11]. If the vertex set is empty, \(S^\varnothing \) has one outcome, even for empty \(S\). An empty alphabet with nonempty vertex set instead gives no outcomes and no real state. Thus zero vertices and an empty configuration set are different cases.
Proposition. Pullback of polynomial functions [fdip-002A]AGENTDRAFTED
- October 23, 2026
Proposition. Pullback of polynomial functions [fdip-002A]AGENTDRAFTED
- October 23, 2026
Let \(V\) be finite, \(J\subseteq V\), \(X=\mathbb R^V\) and \(Y=\mathbb R^J\). Let \(\pi :X\to Y\) restrict a configuration to \(J\). Write \(\mathcal P(X)\) and \(\mathcal P(Y)\) for the algebras of real polynomial functions generated by the coordinate evaluation functions, with pointwise operations and the identity involution. Then \[\begin {aligned} \pi ^*:\mathcal P(Y)&\longrightarrow \mathcal P(X),& P&\longmapsto P\circ \pi \end {aligned}\] is an injective unital real algebra map preserving these involutions. Every supplied real algebraic state on \(\mathcal P(X)\) therefore pulls back to one on \(\mathcal P(Y)\).
Proof.
- October 23, 2026
Proof.
- October 23, 2026
Each coordinate function \(y\mapsto y_j\), \(j\in J\), pulls back to \(x\mapsto x_j\). Composition preserves sums, products, real scalar multiples and constants by pointwise evaluation. Consequently a polynomial function pulls back to a polynomial function and \(\pi ^*\) is a unital real algebra map. Both involutions are the identity, so it preserves star. Define \(s:Y\to X\) by filling coordinates outside \(J\) with zero. Then \(\pi \circ s=\mathrm {id}_Y\). If \(P\circ \pi =Q\circ \pi \), composition with \(s\) gives \(P=Q\), proving injectivity. The state pullback proposition now applies to a supplied state. These arguments also cover \(J=\varnothing \) and \(V=\varnothing \); their real coordinate spaces are singletons, not empty sets.
Here polynomial functions are actual functions, rather than formal polynomial expressions. The proof uses coordinate composition and the zero-fill section, not a finiteness assertion about the real set \(X\). The algebra and positivity conventions are [stacks2017stacks, Section 22.2], Tag 09JF and [waldmann2004states, Definition 3.9, p. 11]. The finite-map construction gives the same contravariant direction, but its finite indicator expansion is not used here.
For the Gaussian expectation, measure and polynomial integrability first establishes that the Gaussian polynomial state on \(\mathcal P(X)\) exists. Once supplied, it restricts by the algebraic result above. Identifying its retained law requires the separate Gaussian marginal calculation. This proposition neither extends that analytic calculation to new degenerate cases nor asserts that all integrable functions form an algebra. Polynomial functions are also distinct from the algebra of field endomorphisms.
Reference measure for real fields [fdip-003U]AGENTDRAFTED
- October 30, 2026
Reference measure for real fields [fdip-003U]AGENTDRAFTED
- October 30, 2026
The 4 real field values on the four-cycle range over an infinite configuration space. Before weighting configurations by an action, a reference volume must specify how they are counted. The counting-coordinate measure assigns volume one to the box in which each field value lies between zero and one, independently of the edge weights and mass. It gives infinite volume to the whole space.
The real field topology and its Borel sets make coordinate maps measurable. Reindexing and splitting preserve product volume, while linear changes require a Jacobian. A subspace's induced volume supplies its own reference measure. These conventions determine the integrals defining positive Gaussian laws and constrained massless laws.
Definition. The topology of real fields [fdip-002C]AGENTDRAFTED
- October 25, 2026
Definition. The topology of real fields [fdip-002C]AGENTDRAFTED
- October 25, 2026
For a finite set \(V\), put \(X_V=\operatorname {Map}(V,\mathbb R)\), the real vertex-field space. Its indicator fields \(\delta _v\) form the finite function basis, so \(x=\sum _{v\in V}x(v)\delta _v\). Use the counting inner product \(h_V(x,y)=\sum _vx(v)y(v)\) and its perfect duality. The carrier \(V\) is finite; the set \(X_V\) of configurations is generally infinite. For \(V=\varnothing \), \(X_V=\{0\}\).
The real field topology is the finite product of the usual topology on \(\mathbb R\). Its basic open sets are boxes \(\prod _{v\in V}O_v\) with every \(O_v\) open.
For a topological space \(Y\), a map \(f:Y\to X_V\) is continuous if and only if every coordinate \(y\mapsto f(y)(v)\) is continuous. Consequently every real linear map between finite field spaces is continuous, and every linear isomorphism is a homeomorphism.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Evaluation \(x\mapsto x(v)\) is continuous by the product topology. Conversely, the inverse image of a basic box is the finite intersection \(\bigcap _v\{y:f(y)(v)\in O_v\}\), which is open if all coordinates are continuous. For a linear map \(T:X_V\to X_W\), the identity \((Tx)(w)=\sum _vx(v)(T\delta _v)(w)\) makes each output coordinate a finite linear combination of continuous inputs. Apply this also to the inverse when \(T\) is invertible. The empty product has the single basic box \(X_\varnothing \); the same statements hold directly.
Pointwise addition, scalar multiplication and \(h_V\) are continuous by finite sums and products of coordinates. The counting form is positive: if \(x\ne 0\), some \(x(v)^2>0\). Its perfectness can also be read directly: for a linear functional \(\ell \), put \(a(v)=\ell (\delta _v)\); then \(\ell (x)=h_V(a,x)\), uniquely by evaluation on the indicators. These are the real specializations of the cited field and duality constructions.
Definition. Borel sets of real fields [fdip-002D]AGENTDRAFTED
- October 25, 2026
Definition. Borel sets of real fields [fdip-002D]AGENTDRAFTED
- October 25, 2026
A sigma-algebra on a set \(X\) is a family of subsets containing \(X\) and closed under complements and countable unions. It is also closed under countable intersections, by taking complements. The Borel sigma-algebra \(\mathcal B(X)\) of a topological space is the smallest sigma-algebra containing all its open sets; see [tao2011measure, Definition 1.4.16, p. 87, preliminary version].
On the real field space, define the coordinate-product sigma-algebra \(\Sigma _V\) to be generated by all cylinders \(\{x:x(v)\in B\}\), where \(v\in V\) and \(B\in \mathcal B(\mathbb R)\). This is the product construction of [tao2011measure, Section 1.7.4, pp. 194-195, preliminary version]. The Borel-product proposition identifies it with \(\mathcal B(X_V)\). We use this Borel structure without completion: no additional subsets of null sets are adjoined.
For the singleton \(X_\varnothing \), the Borel structure is \(\{\varnothing ,X_\varnothing \}\). A product of completed factor sigma-algebras need not be the completed product sigma-algebra; these constructions are distinguished in [tao2011measure, p. 94 and Exercise 1.7.19, p. 195, preliminary version].
Proposition. Borel sets and finite coordinate products [fdip-002E]AGENTDRAFTED
- October 25, 2026
Proposition. Borel sets and finite coordinate products [fdip-002E]AGENTDRAFTED
- October 25, 2026
For every finite real field space, \[\mathcal B(X_V)=\Sigma _V.\] Here \(\Sigma _V\) is the coordinate-product sigma-algebra. This finite-coordinate assertion, including dimension zero, follows by the direct argument below; compare [tao2011measure, Exercises 1.7.18-1.7.19, pp. 194-195, preliminary version].
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Every evaluation is continuous by Definition [fdip-002C]. For fixed \(v\), the subsets of \(\mathbb R\) whose evaluation preimages are Borel form a sigma-algebra containing all open sets, hence all Borel sets. Thus each cylinder is Borel and \(\Sigma _V\subseteq \mathcal B(X_V)\).
Rational open intervals form a countable basis of \(\mathbb R\). Their finite coordinate products form a countable basis of \(X_V\). Each is a finite intersection of cylinder sets and belongs to \(\Sigma _V\). An arbitrary open set is the union of the basis elements it contains; this is a countable union, proving the reverse inclusion. For empty \(V\), the one basic box is the singleton itself, and both sigma-algebras are \(\{\varnothing ,X_V\}\).
Mathlib's Pi.borelSpace requires countable indices,
second-countable topological factors and their Borel measurable structures.
Finite real products meet these assumptions. The less restrictive
pi_le_borel_pi gives only one inclusion, not the displayed equality.
Definition. Measurable observables and maps [fdip-002F]AGENTDRAFTED
- October 25, 2026
Definition. Measurable observables and maps [fdip-002F]AGENTDRAFTED
- October 25, 2026
A measurable map \(f:(X,\Sigma )\to (Y,\mathcal T)\) satisfies \(f^{-1}(B)\in \Sigma \) for every \(B\in \mathcal T\). A Borel observable on \(X_V\) is a measurable real-valued function for \(\mathcal B(X_V)\) and \(\mathcal B(\mathbb R)\). This is the preimage convention of [tao2011measure, Definition 1.4.32 and Remark 1.4.33, pp. 95-96, preliminary version].
Compositions of measurable maps are measurable because \((g\circ f)^{-1}(B)=f^{-1}(g^{-1}(B))\). The coordinate criterion supplies the maps used for real fields. Measurability does not imply integrability. The integrable-observable space is a vector space, whereas polynomial functions form a separate observable algebra; finite \(V\) does not make the configuration set \(X_V\) finite.
Remark. Topology, Borel sets and coordinate observables [fdip-004C]AGENTDRAFTED
- October 31, 2026
Remark. Topology, Borel sets and coordinate observables [fdip-004C]AGENTDRAFTED
- October 31, 2026
On the four-cycle, a configuration is a point \(x=(x_0,x_1,x_2,x_3)\in \mathbb R^4\). The product topology makes \((-1,1)^4\) open. The Borel sigma-algebra also contains the closed half-space \(H=\{x:x_0\le 0\}\), because its complement is open. Thus Borel sets include both open and closed coordinate conditions.
The coordinate observable \(p_0(x)=x_0\) is continuous: the preimage of an open interval is its coordinate cylinder. For every Borel \(A\subseteq \mathbb R\), the set \(p_0^{-1}(A)\) is Borel by the coordinate-product definition and Proposition [fdip-002E], proving measurability. The indicator \(\mathbf 1_H\) is also measurable: its preimage of a Borel set is one of \(\varnothing ,H,H^c,\mathbb R^4\). It is not continuous at the origin, since its values on \((1/k,0,0,0)\), for positive integers \(k\), are all zero while its value at their limit is one.
Mathlib's continuous_apply and
measurable_pi_apply give the coordinate projection facts
for product topologies and product measurable spaces, respectively.
These deductions distinguish topology, measurable sets and measurable maps using the conventions of [tao2011measure, Definitions 1.4.16 and 1.4.32, pp. 87 and 95, preliminary version]. They say nothing by themselves about integrability. For example, the constant observable \(1\) is measurable, but its integral against the coordinate reference measure on \(\mathbb R^4\) is infinite.
Proposition. Coordinate tests for measurable maps [fdip-002G]AGENTDRAFTED
- October 25, 2026
Proposition. Coordinate tests for measurable maps [fdip-002G]AGENTDRAFTED
- October 25, 2026
Let \(V\) be finite and \((Y,\mathcal T)\) a measurable space. A map \(f:Y\to X_V\) is measurable if and only if every map \(y\mapsto f(y)(v)\) to the Borel real line is measurable. Continuous maps between finite real field spaces are Borel measurable. In particular this holds for linear maps, coordinate restriction, zero extension and polynomial functions. Compare [tao2011measure, Exercise 1.4.29 and Remark 1.4.33, pp. 95-96, preliminary version].
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Necessity follows by preimages of cylinders. For sufficiency, the sets \(A\subseteq X_V\) with \(f^{-1}(A)\in \mathcal T\) form a sigma-algebra containing the cylinders; use Proposition [fdip-002E]. For a continuous map, preimages of open sets are open. The same sigma-algebra argument extends this to all Borel sets. Linearity gives continuity by Definition [fdip-002C]; finite sums and products give the polynomial case.
For \(R\subseteq V\), restriction \(\rho _R:X_V\to X_R\) sends \(x\) to \(x|_R\). Zero extension \(\iota _R:X_R\to X_V\) is \(y\) on \(R\) and zero elsewhere. Both are linear and measurable, and \(\rho _R\iota _R=\operatorname {id}_{X_R}\). The reverse composite zeros the removed coordinates and need not be the identity. This is precisely the real polynomial pullback pair, now with its Borel structures; it is not a claim about preserving reference volume.
The product-measurability equivalence is
measurable_pi_iff; it concerns measurable products, without
asserting topology or integrability. For Borel spaces an inducing map
also detects measurability through composition, as in
Topology.IsInducing.measurable_comp_iff; no measurable
range is required. Neither statement attaches a state to every observable.
Definition. Coordinate Lebesgue reference measure [fdip-002H]AGENTDRAFTED
- October 25, 2026
Definition. Coordinate Lebesgue reference measure [fdip-002H]AGENTDRAFTED
- October 25, 2026
Let \(\lambda _{\mathbb R}\) be Lebesgue measure restricted to \(\mathcal B(\mathbb R)\), normalized by \(\lambda _{\mathbb R}(\{x\in \mathbb R:a<x\le b\})=b-a\) for \(a<b\). The coordinate Lebesgue measure of a finite real field space is \[\lambda _V=\bigotimes _{v\in V}\lambda _{\mathbb R}\] on \(\mathcal B(X_V)=\Sigma _V\), characterized on Borel rectangles by \[\lambda _V\left (\prod _v A_v\right ) =\prod _v\lambda _{\mathbb R}(A_v).\] Products lie in \([0,\infty ]\), with \(0\cdot \infty =0\); the empty product is \(1\). The reference is fixed by counting coordinates, independently of any quadratic precision.
Existence follows by induction from the sigma-finite product-measure theorem, [tao2011measure, Proposition 1.7.11, pp. 197-199, preliminary version]. Start with \(\lambda _\varnothing =\delta _0\) on \(X_\varnothing =\{0\}\). Each factor is sigma-finite, and the cubes \([-k,k]^V\), \(k\ge 1\), cover with finite masses \((2k)^{|V|}\). Thus the product is sigma-finite. For nonempty \(V\) these masses grow without bound, so \(\lambda _V(X_V)=\infty \); it is not a probability measure. Finite-cube uniqueness handles its infinite total mass.
The real-spin reference convention appears in [friedli2017statistical, Definition 8.1 and Equation (8.3), p. 381, author version revised 22 August 2017]. The model's boundary conditions and density are additional data. No completion or normalizing density is part of \(\lambda _V\).
Mathlib constructs the finite product as
MeasureTheory.Measure.pi; its rectangle law
MeasureTheory.Measure.pi_pi uses sigma-finite factors.
The product-volume convention is MeasureTheory.volume_pi.
The empty cases MeasureTheory.Measure.pi_of_empty and
MeasureTheory.Measure.pi_empty_univ give Dirac mass and total
mass one, respectively.
Example. Volumes of four-coordinate boxes [fdip-004D]AGENTDRAFTED
- October 31, 2026
Example. Volumes of four-coordinate boxes [fdip-004D]AGENTDRAFTED
- October 31, 2026
Keep the four-cycle carrier \(V=\{0,1,2,3\}\). For real \(a_i\le b_i\), let \[B=\{x\in \mathbb R^4:a_i<x_i\le b_i\text { for }i=0,1,2,3\}.\] The coordinate Lebesgue measure gives \[\lambda _V(B)=\prod _{i=0}^3(b_i-a_i).\] Each factor is the length of its half-open interval, and the defining rectangle law multiplies them. If an endpoint pair is equal, the box is empty and the formula gives zero.
If every lower endpoint is zero and every upper endpoint is one, the box has volume \(1^4=1\). For lower endpoints \((0,0,-1,0)\) and upper endpoints \((2,1,1,3)\), its side lengths are \((2,1,2,3)\), so \[\lambda _V(B)=2\cdot 1\cdot 2\cdot 3=12.\] For \(a_i=-k\) and \(b_i=k\) in all 4 coordinates, with \(k>0\), the volume is \((2k)^4\). These volumes are unbounded as \(k\) increases, so the whole configuration space has infinite volume. Neither the edge weights nor a mass parameter enter these values. Reference volume is not a probability law; the later Gaussian density supplies a normalized weighting.
This is the rectangle formula of Definition [fdip-002H], from
[tao2011measure, Proposition 1.7.11, pp. 197-199, preliminary version].
Mathlib's MeasureTheory.Measure.pi_pi gives the finite-product
rectangle law; Real.volume_Ioc gives each interval length.
Lemma. Uniqueness from finite rational cubes [fdip-002I]AGENTDRAFTED
- October 25, 2026
Lemma. Uniqueness from finite rational cubes [fdip-002I]AGENTDRAFTED
- October 25, 2026
Let \(V\) be finite. Suppose two Borel measures \(\mu ,\nu \) on \(X_V\) agree on all bounded half-open coordinate boxes with rational endpoints and on the empty set. Assume explicitly that their common mass on every rational cube \(C_k=\{x\in X_V:-k<x(v)\le k\text { for every }v\in V\}\), \(k\ge 1\), is finite. Then \(\mu =\nu \). In particular the hypothesis holds if both assign the prescribed finite Lebesgue volumes to those boxes. For empty \(V\), a box is the singleton, and agreement of its mass gives the conclusion.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
For nonempty \(V\), these rational boxes together with the empty set form a pi-system: intersections are again such boxes or empty. Each rational open box is a countable union of half-open rational boxes contained in it, so this pi-system generates the Borel structure by Proposition [fdip-002E]. Fix \(k\). Restrict by \(\mu _k(A)=\mu (A\cap C_k)\) and \(\nu _k(A)=\nu (A\cap C_k)\). The restrictions are finite, have the same finite total mass, and agree on the generating boxes because intersection with \(C_k\) stays in that pi-system.
For completeness, the pi-lambda argument is as follows. A lambda-system contains the whole space and is closed under complements and disjoint countable unions. Let \(\mathcal D\) be the smallest lambda-system containing a pi-system \(\mathcal P\). For \(A\in \mathcal P\), the sets \(B\) satisfying \(A\cap B\in \mathcal D\) form a lambda-system: complement closure uses the difference of two nested members of \(\mathcal D\), and disjoint-union closure is immediate. It contains \(\mathcal P\), hence \(\mathcal D\). Repeating with fixed \(B\in \mathcal D\) shows that \(\mathcal D\) is closed under intersections. Complement and disjoint-union closure then give arbitrary countable unions by disjointification. Thus \(\mathcal D\) is a sigma-algebra.
The class on which \(\mu _k=\nu _k\) is a lambda-system: complements use subtraction from their equal finite total masses, and disjoint unions use countable additivity. It therefore contains every Borel set. Finally \(C_k\uparrow X_V\); continuity from below gives \(\mu (A)=\lim _k\mu _k(A)=\lim _k\nu _k(A)=\nu (A)\). No subtraction of infinite masses occurs.
This is the localized uniqueness argument behind
[tao2011measure, Proposition 1.7.11, pp. 197-199, preliminary version].
Mathlib's MeasureTheory.Measure.pi_eq characterizes a
sigma-finite product by all measurable rectangles. TauCeti's
MeasureTheory.Measure.ext_pi assumes a finite total
first measure; it cannot be applied directly to positive-dimensional
\(\lambda _V\). Bare agreement of arbitrary infinite measures on rational
boxes is not the lemma stated here.
Proposition. Reindexing and splitting reference volume [fdip-002J]AGENTDRAFTED
- October 25, 2026
Proposition. Reindexing and splitting reference volume [fdip-002J]AGENTDRAFTED
- October 25, 2026
For a bijection \(e:V\to W\), define \(U_e:X_V\to X_W\) by \((U_ex)(w)=x(e^{-1}w)\). It is a linear homeomorphism, with inverse \(U_{e^{-1}}\), preserving the counting pairing, and \[(U_e)_*\lambda _V=\lambda _W,\qquad f_*\mu (B):=\mu (f^{-1}B).\] For a disjoint decomposition \(V=R\sqcup D\), the restriction-pair map \(\sigma (x)=(x|_R,x|_D)\) has inverse pasting and satisfies \[\sigma _*\lambda _V=\lambda _R\otimes \lambda _D.\] Either factor may be empty, carrying singleton mass one.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
The displayed maps and inverses are linear, hence continuous by Definition [fdip-002C]. Reindexing the finite sum proves preservation of \(h_V\). For a target rectangle \(\prod _wA_w\), its preimage under \(U_e\) is \(\prod _vA_{e(v)}\). The rectangle formula and reindexing of a finite product give equal measures. The same argument for \(\sigma \) combines the retained and removed coordinate boxes. The target generating boxes have prescribed finite cube masses, so Lemma [fdip-002I] extends both equalities to all Borel sets.
An enumeration \(b:\{1,\ldots ,n\}\to V\) gives the chart \(C_b(x)_i=x(b(i))\). It therefore transports \(\lambda _V\) to ordinary Borel Lebesgue measure on \(\mathbb R^n\); two charts differ by a coordinate permutation. At \(n=0\) both spaces are singletons with mass one. This proves independence of enumeration without a determinant calculation.
These finite-coordinate proofs use the product convention of
[tao2011measure, Section 1.7.4, pp. 194-199, preliminary version].
The corresponding sigma-finite APIs are
MeasureTheory.measurePreserving_piCongrLeft and
MeasureTheory.measurePreserving_piEquivPiSubtypeProd; the latter
uses a decidable splitting predicate. A one-coordinate split is
TauCeti.measurePreserving_piSplitAt, and the specified
four-coordinate grouping is
TauCeti.measurePreserving_finFourArrowPairPair.
Bare restriction \(\rho _R\) is measurable, but if \(D\ne \varnothing \)
it is not reference-preserving: for a Borel \(A\subseteq X_R\) of finite
positive mass, \(\rho _R^{-1}(A)\) has mass
\(\lambda _R(A)\lambda _D(X_D)=\infty \). This includes \(R=\varnothing \),
when the target singleton has mass one. The probability-factor assumption
in TauCeti.measurePreserving_pi_comp_embedding excludes
these unnormalized Lebesgue factors. Normalized marginals are a different
measure statement.
Theorem. Linear changes of reference volume [fdip-002K]AGENTDRAFTED
- October 25, 2026
Theorem. Linear changes of reference volume [fdip-002K]AGENTDRAFTED
- October 25, 2026
Let \(T:X_V\to X_W\) be an invertible real linear map, with \(|V|=|W|=n\). Choose ordered indicator bases and normalized top forms \(\eta _V,\eta _W\), each taking value one on its chosen basis. Define \[T^*\eta _W=d(T)\eta _V,\qquad J(T)=|d(T)|.\] Reordering either basis changes \(d(T)\) only by a sign; \(J(T)>0\) is the reference-volume Jacobian. For Borel sets \(E,B\), \[\begin {aligned} \lambda _W(T(E))&=J(T)\lambda _V(E),\\ T_*\lambda _V(B)&=J(T)^{-1}\lambda _W(B). \end {aligned}\] For nonnegative Borel \(F:X_W\to [0,\infty ]\), \[\int _{X_V}F(Tx)\,d\lambda _V(x) =J(T)^{-1}\int _{X_W}F(y)\,d\lambda _W(y).\] For real signed \(F\), absolute integrability on either side is equivalent to that on the other; under this condition the same equality holds. Translation, and hence \(x\mapsto T(x)+b\), has the same coefficient.
For an endomorphism, \(d(T)=\det T\) only when source and target use the same normalized top form. Independently ordered indicator bases give \(d(T)=\varepsilon \det T\), \(\varepsilon \in \{1,-1\}\), although \(J(T)=|\det T|\). The identity on \(\mathbb R^2\) with reversed target order has \(d=-1\), intrinsic determinant \(1\), and \(J=1\). In dimension zero the top form is \(1\) and \(J=1\).
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Top exterior powers are one-dimensional. For composable maps \(T,S\), use the same intermediate form to obtain \((ST)^*\eta =d(S)d(T)\eta _V\). Thus \(J(ST)=J(S)J(T)\); applying this to \(T^{-1}T\) gives \(J(T^{-1})=J(T)^{-1}\). The absolute identities are independent of enumeration. Since \(T^{-1}\) is continuous, \(T(E)\) is Borel.
On the Borel real line, translation preserves length and multiplication by \(a\ne 0\) has pushforward coefficient \(|a|^{-1}\). Compare preimages of bounded intervals and then use finite-on-bounded-interval uniqueness. When \(a<0\), the reversed half-open interval has the same length since singletons have measure zero. By rectangles and Lemma [fdip-002I], scaling one coordinate has that coefficient. Coordinate permutations preserve measure by Proposition [fdip-002J]. With a common basis their signed top-form multipliers are \(a\) for scaling and \(-1\) for a swap.
For distinct coordinates \(i,j\), the shear \(E(x)=x+c\,x(j)\delta _i\) preserves volume. Split off coordinate \(i\), writing the others as \(z\). For fixed \(z\), translation invariance gives \[\int _{\mathbb R}F(z,t+c\,z(j))\,dt =\int _{\mathbb R}F(z,t)\,dt.\] Nonnegative Tonelli on the sigma-finite uncompleted Borel product then gives equality of full integrals; indicators give measure preservation. The shear's top-form multiplier is \(1\), since replacing the \(j\)th basis vector by \(\delta _j+c\delta _i\) leaves its top wedge unchanged. Tonelli here is [tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version], not the complete-space variant.
These elementary maps generate every isomorphism in indicator charts. Induct on \(n\), the zero-dimensional case being immediate. For \(n>0\), the image of the first basis vector is nonzero. Swap target coordinates to put a nonzero coefficient first, scale it to one, and subtract its suitable multiples from the other target coordinates. The resulting map \(ET\) sends the first domain basis vector to the first target one. If the first coefficient of \((ET)e_j\) is \(a_j\) for \(j>1\), precompose with the domain shears \(e_j\mapsto e_j-a_je_1\). The resulting map fixes the first basis vector and maps the complementary span into the target complementary span. Its restriction is injective; it is surjective because the first coefficient of a preimage of a complementary vector must be zero. Induction on these complements, extending their elementary maps by identity on the first coordinate, completes the factorization.
Pushforwards compose and commute with scalar multiplication of measures. Multiplying the elementary coefficients therefore proves \(T_*\lambda _V=J(T)^{-1}\lambda _W\), after the measure-preserving coordinate charts of Proposition [fdip-002J]. Substituting \(B=T(E)\) gives the image formula. Translations in several coordinates follow from the one-dimensional result and rectangles, yielding the affine assertion. No reciprocal formula is asserted for a singular map.
The integral formula follows first for indicators from the measure identity, then for nonnegative simple functions by additivity, then by increasing simple approximation and monotone convergence. Apply it to \(|F|\) to obtain absolute-integrability equivalence, since \(J(T)\) is positive and finite. Only then apply it to \(F^+,F^-\) and subtract. No multiplication closure of \(L^1\) is used.
The image convention is stated in
[tao2011measure, Exercises 1.2.20-1.2.22, p. 41, preliminary version];
the argument above proves its finite-field form. Mathlib's
Real.map_linearMap_volume_pi_eq_smul_volume_pi is a
finite-coordinate endomorphism theorem with nonzero determinant and
reciprocal pushforward coefficient. Distinct carriers require the
coordinate transport already proved, not an intrinsic signed determinant
between unrelated spaces.
Corollary. Counting isometries preserve volume [fdip-002L]AGENTDRAFTED
- October 25, 2026
Corollary. Counting isometries preserve volume [fdip-002L]AGENTDRAFTED
- October 25, 2026
A linear isomorphism \(T:X_V\to X_W\) preserving the counting inner products satisfies \(J(T)=1\). It therefore preserves coordinate Lebesgue measure and the integrals in Theorem [fdip-002K]. An isometric embedding into a higher-dimensional space is not included.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
The vectors \(T\delta _v\) form an orthonormal basis. On simple top exterior vectors the induced inner product is \[\left \langle u_1\wedge \cdots \wedge u_n, v_1\wedge \cdots \wedge v_n\right \rangle =\det \bigl (h(u_i,v_j)\bigr ).\] Alternating multilinearity makes this well-defined on the top exterior power. The wedge of an ordered orthonormal basis has squared norm one, and an isometry preserves every entry of the displayed Gram matrix. Consequently \(d(T)^2=1\), so \(J(T)=1\); apply Theorem [fdip-002K]. The empty wedge also has norm one.
This is a direct consequence of the preceding transformation theorem,
with the convention of
[tao2011measure, Exercise 1.2.21, p. 41, preliminary version].
Mathlib's LinearIsometryEquiv.measurePreserving concerns
finite-dimensional real inner-product spaces with compatible Borel
structures and their canonical volumes. An arbitrary perfect pairing
or a general quadratic-form isometry does not supply these hypotheses.
Definition. Induced Euclidean volume on a subspace [fdip-002M]AGENTDRAFTED
- October 25, 2026
Definition. Induced Euclidean volume on a subspace [fdip-002M]AGENTDRAFTED
- October 25, 2026
Let \(H\) be a finite-dimensional real inner-product space, in particular a subspace of \((X_V,h_V)\) with its induced topology and inner product. Choose an orthonormal chart \(C:H\to \mathbb R^k\). The induced Euclidean measure is \(\lambda _H=(C^{-1})_*\lambda _{\{1,\ldots ,k\}}\) on its Borel sets. It is independent of the orthonormal chart. If \(H=\{0\}\), it is unit mass at zero. For an affine translate \(a+H\), use the pushforward of \(\lambda _H\) under \(h\mapsto a+h\).
Proof.
- October 25, 2026
Proof.
- October 25, 2026
A finite Gram-Schmidt construction produces an orthonormal basis: normalize a nonzero vector by its positive norm, subtract its components from a spanning family, and continue in the orthogonal complement. Positivity permits normalization at each nonzero step. Two such charts differ by a linear isometric isomorphism of \(\mathbb R^k\); Corollary [fdip-002L] proves independence. A different choice of origin in \(a+H\) differs by a translation in \(H\), which preserves its coordinate measure by Theorem [fdip-002K].
For a proper linear subspace \(H\subsetneq X_V\), extend its orthonormal basis to one of \(X_V\) by the same construction. In those coordinates \(H\) lies in a coordinate hyperplane and is closed. Within each bounded cube that hyperplane has measure zero: the rectangle formula has a zero-measure singleton factor and finite other factors. Monotonicity and countable exhaustion give zero ambient measure; orthogonal invariance transports this back. But the unit coordinate cube in \(H\) has induced mass one. Thus induced volume is not the restriction of ambient \(\lambda _V\).
For example, on \(H=\{(s,s):s\in \mathbb R\}\), the segment \(0\le s\le 1\) has induced length \(\sqrt 2\), ambient area zero, and raw \(s\)-coordinate length one. Indeed its unit vector is \((1,1)/\sqrt 2\), so its orthonormal coordinate runs from zero to \(\sqrt 2\). An arbitrary basis therefore needs its volume factor.
The argument uses the transformation convention of
[tao2011measure, Exercise 1.2.21, p. 41, preliminary version].
Mathlib's OrthonormalBasis.measurePreserving_repr targets
EuclideanSpace; PiLp.volume_preserving_ofLp and
PiLp.volume_preserving_toLp identify its real finite PiLp
volume with ordinary coordinate products. TauCeti's
Module.Basis.volume_eq_smul_addHaar records the
square-root Gram determinant factor for an arbitrary basis, while
AffineIsometryEquiv.measurePreserving applies to
finite-dimensional real Borel inner-product spaces. These compare the
same canonical-volume convention.
Example. Image volume and pushforward mass [fdip-002N]AGENTDRAFTED
- October 25, 2026
Example. Image volume and pushforward mass [fdip-002N]AGENTDRAFTED
- October 25, 2026
On the Borel real line, let \(T(x)=2x\). The
Jacobian theorem gives \(J(T)=2\), but its two measure
directions have reciprocal coefficients:
\[\lambda _{\mathbb R}(T[0,1])=2,\qquad
T_*\lambda _{\mathbb R}([0,1])=\tfrac 12.\]
The first set is \([0,2]\), whereas the second expression measures the
preimage \([0,1/2]\). This directly checks the convention of
[tao2011measure, Exercise 1.2.21, p. 41, preliminary version].
Mathlib's Real.map_volume_mul_left requires a nonzero scalar
and gives the reciprocal absolute pushforward factor.
Put \(q_V(x)=x^2\) and \(q_W(y)=y^2/4\). Then \(q_W(Tx)=q_V(x)\) although \(J(T)=2\). Preserving a quadratic form alone does not preserve the supplied reference volume.
If a Borel weight \(w\ge 0\) has a finite positive integral \(Z=\int w\,d\lambda _V\), replacing the reference by \(c\lambda _V\), \(c>0\), replaces \(Z\) by \(cZ\). Consequently \((cZ)^{-1}w\,d(c\lambda _V)=Z^{-1}w\,d\lambda _V\). This conditional cancellation follows from linearity for indicators, simple functions and monotone limits. It proves neither existence nor finiteness of \(Z\); the reference and the action are separate data.
Lemma. Orthogonal sums have product volume [fdip-002Q]AGENTDRAFTED
- October 25, 2026
Lemma. Orthogonal sums have product volume [fdip-002Q]AGENTDRAFTED
- October 25, 2026
Let \(E=E_1\mathbin \perp E_2\) be an orthogonal direct sum of finite-dimensional real inner-product spaces. Use their canonical Euclidean volumes on the uncompleted Borel sigma-algebras. Addition \(a(x_1,x_2)=x_1+x_2\) is a measure-preserving isometric isomorphism: \[a_*(\lambda _{E_1}\otimes \lambda _{E_2})=\lambda _E.\] All these measures are sigma-finite. Nonnegative Borel functions therefore satisfy Tonelli's iterated-integral identities. For a real Borel function with finite absolute integral, Fubini holds and its sections are integrable almost everywhere.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Concatenate orthonormal bases of \(E_1\) and \(E_2\). The resulting orthonormal chart of \(E\) turns addition into concatenation of coordinate tuples. The finite product splitting identifies the measures, and chart independence is already proved at Definition [fdip-002M]. Empty bases give singleton factors of mass one, so the argument includes zero summands.
Each finite chart is exhausted by cubes \([-N,N]^n\) of finite measure; in dimension zero the whole measure has mass one. Thus [tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version] applies to these uncompleted sigma-finite products. Applying Tonelli to the absolute value shows that section integrals of the absolute value are finite almost everywhere. Applying it to positive and negative parts then gives signed Fubini. The null-section statement in [tao2011measure, Corollary 1.7.17, pp. 201-202, preliminary version] concerns product-null sets; it does not remove the absolute-integrability hypothesis for signed integrals.
This follows from canonical Euclidean volume and finite product splitting.
Mathlib's LinearIsometryEquiv.measurePreserving supports the
isometry step for finite-dimensional real Borel inner-product spaces with
canonical volume; arbitrary perfect pairings do not supply these hypotheses.
Positive Gaussian laws and covariance [fdip-0017]AGENTDRAFTED
- October 20, 2026
Positive Gaussian laws and covariance [fdip-0017]AGENTDRAFTED
- October 20, 2026
A positive quadratic action weights large fields less heavily. Does its integral over an infinite field space converge, and what expectations does the normalized weight assign? The alternating four-cycle calculation answers both questions explicitly: its 4 precision eigenvalues determine the normalizer and the correlation between opposite vertices. The reference volume is fixed before this weight is chosen.
A positive quadratic action on a finite real inner-product space has a finite Gaussian normalizer. Absolute polynomial moments make its expectation a polynomial state, and the covariance theorem identifies inverse precision as its covariance operator. Zero modes require the separate constraints used for massless laws. Averaging or fixing some fields will later give the distinct marginal and conditional laws.
Lemma. A finite real self-adjoint spectral decomposition [fdip-002R]AGENTDRAFTED
- October 25, 2026
Lemma. A finite real self-adjoint spectral decomposition [fdip-002R]AGENTDRAFTED
- October 25, 2026
Let \((E,h)\) be a real inner-product space of dimension \(n\geq 0\), and let \(T:E\to E\) be linear and self-adjoint. There is an orthonormal basis \(u_1,\ldots ,u_n\) with real eigenvalues \(q_i\). Put \(P_ix=h(u_i,x)u_i\). Then \[\begin {aligned} I&=\sum _iP_i,&T&=\sum _iq_iP_i,\\ P_iP_j&=\delta _{ij}P_i,&\det T&=\prod _iq_i. \end {aligned}\] Moreover \(h(x,Tx)>0\) for every nonzero \(x\) exactly when every \(q_i>0\). In that case \(T^{-1}=\sum _iq_i^{-1}P_i\) is self-adjoint and positive.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
For \(n>0\), maximize the continuous function \(x\mapsto h(x,Tx)\) on the compact unit sphere. Let \(u\) be a maximizing unit vector and \(q=h(u,Tu)\). If \(v\perp u\), the Rayleigh quotient \[\frac {h(u+tv,T(u+tv))}{1+t^2h(v,v)}\] has derivative zero at \(t=0\). Self-adjointness gives derivative \(2h(v,Tu)\), so \(Tu-qu\) is orthogonal both to \(u^\perp \) and to \(u\). It is zero. Also \(h(u,Tv)=h(Tu,v)=qh(u,v)=0\) on \(u^\perp \), so this complement is stable and the restriction is self-adjoint. Induction gives the basis; the base case \(n=0\) is the empty basis.
Orthonormal expansion proves the projector identities. On the top exterior power, \(\bigwedge ^nT\) multiplies \(u_1\wedge \cdots \wedge u_n\) by \(\prod _iq_i\). This scalar is independent of the nonzero top generator and is the intrinsic determinant. Necessity of positive eigenvalues follows by evaluating at \(u_i\); sufficiency follows from \[h(x,Tx)=\sum _iq_i h(u_i,x)^2.\] Multiplying the projector sums proves the asserted inverse and its positivity. For \(n=0\), the empty product is one and the unique endomorphism is the identity, invertible and vacuously positive.
This gives the operator proof of the real symmetric decomposition in
[boyd2004convex, Appendix A.5.2, pp. 646-647].
Mathlib's LinearMap.IsSymmetric.eigenvectorBasis supplies an
orthonormal eigenbasis for a finite-dimensional inner-product space;
here its scalar field is specialized to \(\mathbb R\). The declaration
alone asserts neither Gaussian normalization nor a graph spectrum.
Definition. Positive quadratic actions [fdip-0004]AGENTDRAFTED
- October 16, 2026
Definition. Positive quadratic actions [fdip-0004]AGENTDRAFTED
- October 16, 2026
Let \((E,h)\) be a finite-dimensional real inner-product space, with \(n=\dim E\geq 0\), its finite-dimensional topology, Borel sigma-algebra and canonical Euclidean volume. The field specialization is \(E=X_V=\operatorname {Map}(V,\mathbb R)\) for a finite vertex set, including the empty set, with counting inner product \(h_V(x,y)=\sum _{v\in V}x(v)y(v)\) and coordinate Lebesgue measure. There are finitely many coordinates but, in positive dimension, continuously many configurations. Real-spin integration uses this reference convention in [friedli2017statistical, Definition 8.1 and Equation (8.3), author version p. 381]. The extension to \((E,h)\) is the same paired construction in an orthonormal chart; it asserts no ring-general probability law.
A positive precision parameter is a real linear endomorphism \(Q:E\to E\) that is self-adjoint for \(h\) and strictly positive: \(h(x,Qx)>0\) for every \(x\ne 0\). Define its symmetric bilinear form and associated quadratic form by \[b_Q(x,y)=h(x,Qy),\qquad q_Q(x)=b_Q(x,x).\] Linearity in both slots follows from linearity of \(Q\) and the pairing. Self-adjointness gives \(b_Q(y,x)=h(Qy,x)=h(y,Qx)=b_Q(x,y)\). Consequently \[q_Q(x+y)-q_Q(x)-q_Q(y)=2b_Q(x,y).\] Also \(q_Q(cx)=c^2q_Q(x)\) for every real \(c\). This is the quadratic form used here; positivity of its diagonal alone would not assert self-adjointness of an arbitrary endomorphism.
Its Euclidean quadratic action and Boltzmann weight are \[\begin {aligned} S_Q(x)&=\frac 12 q_Q(x)=\frac 12h(x,Qx),\\ w_Q(x)&=\exp (-S_Q(x)). \end {aligned}\] Thus \(q_Q=2S_Q\), \(S_Q(0)=0\), and \(S_Q(x)>0\) off zero. Dividing the polarization identity by two gives \[S_Q(x+y)-S_Q(x)-S_Q(y)=b_Q(x,y).\] The finite-coordinate formulas make \(S_Q\) continuous, hence Borel measurable, and so is its exponential. In particular \(0<w_Q(x)\le 1\), with equality \(w_Q(x)=1\) exactly when \(x=0\). This bound does not prove integrability on a space of infinite reference volume; Gaussian normalization supplies that separate argument.
The counting-array bridge recovers the familiar symmetric matrix and \(x^TQx\) notation from this operator definition. The variables and coefficients here are dimensionless: their chosen scales are absorbed into \(Q\). Wingate's Euclidean convention is \(\exp (-S)\); his lattice-spacing factors belong to his lattice model [wingate2025lattice, Sections 3-4, Equations (3.1) and (4.1)-(4.6), pp. 2-3]. This real nonnegative weight supplies no real-time evolution. The complete four-cycle action gives the concrete operator, array, half factor and test-field value.
Remark. The counting array of a precision operator [fdip-002O]AGENTDRAFTED
- October 25, 2026
Remark. The counting array of a precision operator [fdip-002O]AGENTDRAFTED
- October 25, 2026
Let \(Q:X_V\to X_V\) be a positive precision parameter. Choose an indicator enumeration and its counting chart \(C:X_V\to \mathbb R^n\). Write \(A=CQC^{-1}\) for the resulting array. Then \[h_V(x,Qy)=(Cx)^TA(Cy).\] Thus \(Q\) is self-adjoint exactly when \(A^T=A\), and is strictly positive exactly when \(z^TAz>0\) for every nonzero \(z\). The action is \(S_Q(x)=\tfrac 12(Cx)^TA(Cx)\).
Proof.
- October 25, 2026
Proof.
- October 25, 2026
The chart sends the indicator basis to the standard orthonormal basis, so the counting pairing becomes the ordinary dot product. Substitution yields the displayed identity. Testing it on every pair of basis vectors proves the symmetry equivalence; bijectivity of \(C\) proves the positivity equivalence. Using this same basis for source and target gives \(\det A=\det Q\); a simultaneous re-enumeration conjugates \(A\) by a permutation matrix and does not change the determinant.
In the ensuing Gaussian formulas, the customary matrix symbol \(Q\) denotes this counting array of the endomorphism. An arbitrary nonorthonormal chart need not make its array symmetric: its Gram matrix must also enter the pairing. This calculation is a coordinate recovery of Definition [fdip-0004], not a new normalization result. The half-action convention agrees with [wingate2025lattice, Section 4, Equation (4.5), p. 3].
Example. The positive action of the alternating cycle [fdip-002P]AGENTDRAFTED
- October 25, 2026
Example. The positive action of the alternating cycle [fdip-002P]AGENTDRAFTED
- October 25, 2026
Use the four-cycle oriented \(0\to 1\to 2\to 3\to 0\), with edge weights \((1,t,1,t)\), \(t>0\). Let \(D:X_V\to X_E\) evaluate endpoint differences and \(W\) multiply by the supplied edge weights. With counting adjoint \(D^\dagger \), put \[L=D^\dagger WD,\qquad Q=L+m^2\operatorname {id},\qquad m>0.\] For every \(x,y\), the energy interface gives \[h_V(x,Ly)=\sum _e w(e)(Dx)(e)(Dy)(e).\] It is symmetric in \(x,y\), so \(Q\) is self-adjoint. On the diagonal all edge terms are nonnegative and \(m^2h_V(x,x)>0\) off zero. Thus \(Q\) is a positive precision parameter. At zero mass constant fields instead expose the Laplacian kernel.
In the specified vertex order \((0,1,2,3)\), write \(x=(a,b,c,d)\). The 4 differences are \(b-a,c-b,d-c,a-d\), so the action is exactly \[\begin {aligned} 2S_{t,m}(a,b,c,d) &=(b-a)^2+t(c-b)^2\\ &\quad +(d-c)^2+t(a-d)^2\\ &\quad +m^2(a^2+b^2+c^2+d^2). \end {aligned}\] Each edge occurs once, with one half of its weighted energy in \(S\). Every summand of \(2S\) is nonnegative, with strict positivity off zero from the mass term.
Set \(s=1+t+m^2\). The 4 edge outer products, equivalently expansion of the 4 squares, give diagonal coefficient \(s\), cross terms \(-2ab\), \(-2tbc\), \(-2cd\), \(-2tad\), and no \(ac\) or \(bd\) term. The counting array is therefore \[Q_{t,m}=\begin {pmatrix} s&-1&0&-t\\ -1&s&-t&0\\ 0&-t&s&-1\\ -t&0&-1&s \end {pmatrix}.\] Multiplication recovers \(x^TQ_{t,m}x=2S_{t,m}(x)\). For \(x=(0,1,0,0)\), the edge energy is \(1+t\) and the mass energy is \(m^2\); hence \(S_{t,m}(0,1,0,0)=s/2\), explicitly \(3/2\) when \(t=m=1\). No change of basis or reference measure occurs.
This is a direct calculation in the supplied cycle data, with the edge-once convention of [spielman2009effective, Section 2.1, pp. 4-5] and the positive kinetic sign and half-action of [wingate2025lattice, Section 4, Equation (4.5), p. 3]. All coefficients here are dimensionless. No Gaussian normalizer or covariance is inferred from the energy calculation.
Example. Edge energy and the positive action [fdip-001R]AGENTDRAFTED
- October 20, 2026
Example. Edge energy and the positive action [fdip-001R]AGENTDRAFTED
- October 20, 2026
For the real alternating four-cycle, take \(t,m>0\) and let \(L_t\) be the weighted Laplacian. Its positive precision parameter is exactly \[Q_{t,m}=L_t+m^2I.\] Indeed, the displayed array of \(L_t\) has diagonal \(1+t\) and the same off-diagonal entries as the action's precision. Adding \(m^2I\) changes that diagonal to \(1+t+m^2\), giving the displayed \(Q_{t,m}\) in Example [fdip-002P].
For \(f=(a,b,c,d)\), the Euclidean quadratic action is therefore \[\begin {aligned} S_{t,m}(f) &=\frac 12\langle f,L_tf\rangle _V +\frac {m^2}{2}\langle f,f\rangle _V\\ &=\frac 12\bigl ((b-a)^2+t(c-b)^2\\ &\qquad \quad +(d-c)^2+t(a-d)^2\bigr )\\ &\qquad +\frac {m^2}{2}(a^2+b^2+c^2+d^2). \end {aligned}\] This is the same squared-difference formula as in Example [fdip-002P]: half of the edge-once energy plus the mass term. The first summand is nonnegative, and the mass summand is positive for \(f\ne 0\). This calculation compares the graph convention of [spielman2009effective, Section 2.1, pp. 4-5] with the positive kinetic sign and half-action convention of [wingate2025lattice, Section 4, Equation (4.5), p. 3]; the finite four-cycle equality follows by the substitutions above.
Lemma. The scalar Gaussian integral [fdip-002S]AGENTDRAFTED
- October 25, 2026
Lemma. The scalar Gaussian integral [fdip-002S]AGENTDRAFTED
- October 25, 2026
For real \(a\), consider the extended nonnegative Lebesgue integral \[I(a)=\int _{\mathbb R}e^{-a x^2/2}\,dx.\] For \(a>0\) it is finite and positive, and \[I(a)=\sqrt {2\pi /a},\qquad I(1)^2=2\pi .\] For \(a\leq 0\) it is infinite.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Suppose \(a>0\). The continuous integrand is at most one on \([-1,1]\). For \(|x|\geq 1\), it is at most \(e^{-a|x|/2}\), whose integral on \(\mathbb R\) is \(4/a\). This proves finiteness before evaluation. On \([-1,1]\) the integrand is at least \(e^{-a/2}\), giving the strictly positive lower bound \(2e^{-a/2}\).
Set \(J=\int _0^\infty e^{-x^2}\,dx\), likewise finite and positive. For each fixed \(y>0\), the substitution \(x=yt\) gives \(J=\int _0^\infty y e^{-y^2t^2}\,dt\). Multiply by \(e^{-y^2}\), integrate in \(y\), and apply nonnegative Tonelli: \[\begin {aligned} J^2&=\int _0^\infty \int _0^\infty y e^{-(1+t^2)y^2}\,dy\,dt\\ &=\int _0^\infty \frac {dt}{2(1+t^2)}=\frac \pi 4. \end {aligned}\] The inner primitive is \(-e^{-(1+t^2)y^2}/(2(1+t^2))\); the final integral is evaluated by arctangent. Thus \(J=\sqrt {\pi }/2\). Reflection and the positive substitution \(x=\sqrt {2/a}\,z\) give the asserted value of \(I(a)\). If \(a\leq 0\), the integrand is at least one everywhere and its nonnegative integral is infinite.
The calculation adapts Keith Conrad's improper-integral argument in
[conradGaussianIntegral, Section 2, Second proof: Another change of variables, PDF pp. 1-2]
to Lebesgue integration. The explicit tail bound and nonnegative Tonelli
justify the adaptation; Tonelli is
[tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version].
Mathlib's integrable_exp_neg_mul_sq and
integral_gaussian support the real one-variable result with
coefficient \(b=a/2>0\). The value theorem uses a totalized integral;
its value at a nonintegrable parameter does not mean the nonnegative
normalizer is finite.
Theorem. Finite positive Gaussian normalization [fdip-002T]AGENTDRAFTED
- October 25, 2026
Theorem. Finite positive Gaussian normalization [fdip-002T]AGENTDRAFTED
- October 25, 2026
Let \((E,h)\) be a finite-dimensional real inner-product space, \(n=\dim E\geq 0\), and let \(Q:E\to E\) be self-adjoint. With the canonical h-volume, put locally \[Z=\int _E\exp \bigl (-h(x,Qx)/2\bigr )\,d\lambda _E(x).\] This nonnegative integral is finite if and only if \(Q\) is strictly positive. In that case \[0<Z=\frac {(2\pi )^{n/2}}{\sqrt {\det Q}}<\infty .\] For \(n=0\), the determinant and normalizer are both one.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Use the orthonormal eigenbasis, with eigenvalues \(q_i\). Its coordinates \(y_i=h(u_i,x)\) preserve canonical volume and give \[\begin {aligned} \frac 12h(x,Qx)&=\frac 12\sum _iq_i y_i^2,\\ \exp \bigl (-h(x,Qx)/2\bigr )&=\prod _i e^{-q_i y_i^2/2}. \end {aligned}\] If \(Q\) is positive, every \(q_i>0\). Repeated nonnegative Tonelli and the scalar integral yield \[Z=\prod _i I(q_i) =\frac {(2\pi )^{n/2}}{\sqrt {\prod _iq_i}}.\] The spectral determinant identity proves the formula. For an empty basis the product and the singleton volume are one.
Conversely, if \(Q\) is not positive, self-adjointness and the spectral lemma give an eigenvalue \(q_i\leq 0\). Restrict the other coordinates to \([-1,1]\). Their product weight is bounded below there by \(c=\exp (-\tfrac 12\sum _{j\ne i}\max (q_j,0))>0\). On the box with \(|y_i|\leq R\), the remaining factor is at least one, so the weight integral is at least \(c\,2^{n-1}(2R)\). These bounds diverge as \(R\to \infty \). This avoids any product of zero and infinity. In dimension zero nonpositivity cannot occur.
For the spectral input, see [boyd2004convex, Appendix A.5.2, pp. 646-647]. For the scalar integral, see Keith Conrad's [conradGaussianIntegral, Section 2, PDF pp. 1-2]. The density convention in [friedli2017statistical, Lemma B.54 and Proposition B.55, pp. 504-505] is a comparison, not an assumption of normalization: that source uses a covariance parameter, while \(Q\) here is precision. For the counting field space, the array bridge recovers the customary determinant formula without changing its reference volume.
Definition. The Gaussian partition function and probability law [fdip-0005]AGENTDRAFTED
- October 25, 2026
Definition. The Gaussian partition function and probability law [fdip-0005]AGENTDRAFTED
- October 25, 2026
Let \(Q\) be a positive precision parameter on a finite real inner-product space \((E,h)\), with canonical volume \(\lambda _E\). Its Gaussian partition function is \[Z_Q=\int _E w_Q\,d\lambda _E, \qquad w_Q(x)=e^{-h(x,Qx)/2}.\] The normalization theorem proves \[0<Z_Q=\frac {(2\pi )^{n/2}}{\sqrt {\det Q}}<\infty , \qquad n=\dim E.\] Its Gaussian probability law is the Borel measure \[\mu _Q(A)=Z_Q^{-1}\int _A w_Q\,d\lambda _E.\] In the counting field specialization this is exactly the density \(Z_Q^{-1}\exp (-\phi ^TQ\phi /2)\) against the product reference measure.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
The weight is positive Borel. Nonnegativity and the empty-set axiom follow from the nonnegative integral. For pairwise disjoint Borel \(A_k\), the functions \(w_Q\sum _{k=1}^N\mathbf 1_{A_k}\) increase to \(w_Q\mathbf 1_{\bigcup _k A_k}\). Monotone convergence and finite additivity of the integral give countable additivity after division by \(Z_Q\). The total mass is \(Z_Q/Z_Q=1\).
In an orthonormal eigenchart the density is the product of the centered scalar densities \(I(q_i)^{-1}e^{-q_i y_i^2/2}\). This identification uses the scalar value and normalization, before computing covariance. For \(n=0\), the action is zero at the unique point, \(Z_Q=1\), and \(\mu _Q=\delta _0\). Replacing the reference volume by \(c\lambda _E\), \(0<c<\infty \), multiplies \(Z_Q\) by \(c\) and leaves \(\mu _Q\) unchanged, as in the reference-rescaling example. A finite-sum partition function has the same normalizing role. A finite vertex set gives a finite-dimensional configuration space. Integrability of its Gaussian weight follows from the normalization theorem, using positive precision.
The density convention is compared with [friedli2017statistical, Lemma B.54 and Proposition B.55, pp. 504-505]; that source uses covariance rather than precision. Countable additivity uses [tao2011measure, Theorem 1.4.44, pp. 107-108, preliminary version]. The normalization failures distinguish infinite normalizers, zero weights and the zero-dimensional case.
Example. Three failures of normalization [fdip-002U]AGENTDRAFTED
- October 25, 2026
Example. Three failures of normalization [fdip-002U]AGENTDRAFTED
- October 25, 2026
The normalization theorem distinguishes infinite mass from zero mass. In positive dimension, zero precision has \(S=0\) and weight one, so its integral is the infinite Euclidean volume. Invertibility alone is insufficient: on \(\mathbb R^2\), \(Q=\operatorname {diag}(1,-1)\) has weight \(e^{-x^2/2+y^2/2}\). On \(|x|\leq 1\) the first factor is at least \(e^{-1/2}\), while the integral in \(y\) diverges. Neither weight defines the normalized Gaussian law on that full space.
For a general nonnegative weight \(w\equiv 0\), the integral is zero, so division cannot normalize it. This differs from zero precision. On \(E=0\), the unique endomorphism is invertible and vacuously positive, its Gaussian weight is one, and its normalizer is one. A singular law on a proper subspace requires that subspace's own reference measure; inserting a pseudoinverse does not normalize a divergent ambient density.
These calculations use the spectral and scalar ingredients of Theorem [fdip-002T]. For the scalar distinction, see Keith Conrad's [conradGaussianIntegral, Section 2, PDF pp. 1-2]; the explicit bounds are proved in Lemma [fdip-002S].
Remark. Polynomial functions do not depend on a basis [fdip-002V]AGENTDRAFTED
- October 25, 2026
Remark. Polynomial functions do not depend on a basis [fdip-002V]AGENTDRAFTED
- October 25, 2026
For a finite-dimensional real vector space \(E\), the actual polynomial function algebra used in Proposition [fdip-002A] is independent of coordinates. It is the real unital subalgebra of functions \(E\to \mathbb R\) generated by linear functionals. In a chosen basis, every linear functional is a finite linear combination of coordinate evaluations. Conversely every coordinate evaluation is linear. Thus these generators give exactly the coordinate polynomial algebra of that note. Substituting linear combinations in a finite polynomial gives a finite polynomial, so changing basis preserves the algebra.
Its operations and identity involution are pointwise, and its functions are continuous, hence Borel for the finite-dimensional topology. For \(E=0\), the algebra consists of constants. These are actual functions; formal polynomial expressions and their polynomial rings are related algebraic vocabulary, not a second choice of observable functions here.
This coordinate-independence argument is a direct deduction from the generators. The algebra and star conventions are those already used in Proposition [fdip-002A]. For these conventions, see [stacks2017stacks, Section 22.2], Tag 09JF and [waldmann2004states, Definition 3.9, p. 11]. Neither citation asserts Gaussian integrability.
Proposition. Every polynomial has finite absolute Gaussian moments [fdip-002W]AGENTDRAFTED
- October 25, 2026
Proposition. Every polynomial has finite absolute Gaussian moments [fdip-002W]AGENTDRAFTED
- October 25, 2026
Let \(Q\) be positive self-adjoint on a finite real inner-product space \((E,h)\), with weight \(w_Q=e^{-h(x,Qx)/2}\) and canonical volume. Every actual polynomial function satisfies \[\int _E |P(x)|w_Q(x)\,d\lambda _E(x)<\infty .\] This holds for every finite product and power of polynomials, including \(P^2\), and therefore also for integration against the normalized law.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
First take an integer \(k\geq 0\) and \(a>0\). Put \(c=a/4\), choose an integer \(M\geq k/2\), and set \(C=\max (1,M!c^{-M})\). For \(|x|\geq 1\), the exponential series gives \(e^{cx^2}\geq (cx^2)^M/M!\), hence \[|x|^k e^{-a x^2/2}\leq M!c^{-M} e^{-a x^2/4}.\] For \(|x|\leq 1\), the left side is at most \(e^{-a x^2/2}\), which is at most \(e^{-a x^2/4}\). The global bound therefore holds with \(C\) and includes \(k=M=0\). Its right side is integrable by the scalar lemma with parameter \(a/2\).
In an orthonormal eigenchart, write \[\begin {aligned} P(x)&=\sum _\alpha c_\alpha \prod _i y_i^{\alpha _i},\\ w_Q(x)&=\prod _i e^{-q_i y_i^2/2}. \end {aligned}\] There are finitely many nonnegative-integer multiindices \(\alpha \). Nonnegative Tonelli factors the weighted absolute integral of each monomial into finite scalar integrals just proved. The triangle inequality bounds the polynomial integral by the finite sum of these integrals multiplied by \(|c_\alpha |\). Products and powers remain polynomials, so the same argument applies. In dimension zero each function is constant and its integral is its absolute value at zero.
The envelope estimate and finite-sum argument are direct deductions
from Keith Conrad's [conradGaussianIntegral, Section 2, PDF pp. 1-2] and
[tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version].
The orthogonal reduction agrees with
[friedli2017statistical, Lemma B.54, p. 504].
TauCeti's TauCeti.integrable_eval_mul_gaussianEnvelope
supports the one-variable polynomial envelope with mean zero and
variance \(w=1/a>0\). The finite products, coordinate substitution and
algebra closure above are separate arguments; no inverse-covariance
identity is used.
Definition. Integrable observables and Gaussian expectation [fdip-0006]AGENTDRAFTED
- October 25, 2026
Definition. Integrable observables and Gaussian expectation [fdip-0006]AGENTDRAFTED
- October 25, 2026
For the Gaussian probability law \(\mu _Q\) on \((E,h)\), an integrable observable is a Borel function \(F:E\to \mathbb R\) with \(\int _E|F|\,d\mu _Q<\infty \). Its Gaussian expectation is \[\begin {aligned} \omega _Q(F)=\langle F\rangle _Q&=\int _E F\,d\mu _Q\\ &=Z_Q^{-1}\int _E F(x)w_Q(x)\,d\lambda _E(x). \end {aligned}\] The equality follows first for nonnegative simple functions from the density definition, then by monotone convergence, and finally by positive and negative parts for an absolutely integrable function.
These actual functions form a real vector space: the pointwise bound \(|aF+bG|\leq |a||F|+|b||G|\) proves closure, and integration is real linear on it. One may instead take almost-everywhere classes when using \(L^1\); polynomial observables here remain actual functions. All polynomial moments give its polynomial subalgebra; the state proposition proves normalization, positivity and Hermiticity there. The integrable-domain example explains why the full vector space need not be an algebra.
This extends finite expectation: absolute integrability replaces automatic convergence of a finite sum. The real-spin convention is [friedli2017statistical, Definition 8.1 and Equation (8.3), p. 381]; the density-integral extension uses [tao2011measure, Theorem 1.4.44, pp. 107-108, preliminary version]. Constants and oddness give the vanishing linear means. Covariance and variance extend the finite convention of Notation [ftip-008H]; the partition function, two-point expectation and other observable expectations remain distinct quantities.
Proposition. Gaussian expectation is a polynomial state [fdip-002X]AGENTDRAFTED
- October 25, 2026
Proposition. Gaussian expectation is a polynomial state [fdip-002X]AGENTDRAFTED
- October 25, 2026
For positive self-adjoint \(Q\) on a finite real inner-product space, its expectation restricts to a real algebraic state on the actual polynomial function algebra, with identity involution.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Absolute polynomial moments make the integral defined on the entire algebra, including every square. Linearity of integration gives real linearity. The probability law gives \(\omega _Q(1)=1\). Positivity follows from \[\omega _Q(P^*P)=\omega _Q(P^2)\geq 0.\] Hermiticity is a separate check: since \(P^*=P\) and conjugation on \(\mathbb R\) is the identity, \(\omega _Q(P^*)=\omega _Q(P)\). More generally every pointwise nonnegative polynomial has nonnegative expectation. In dimension zero this is evaluation at zero on constants.
This is the direct integral realization of the convention in [waldmann2004states, Section 3.1, p. 9; Definitions 3.7 and 3.9, Remark 3.10(iv), p. 11], specialized to ordinary real coefficients as in Definition [fdip-0024]. A supplied unital star-compatible algebra map permits state pullback, in particular the coordinate restriction pullback. This asserts neither an automatic Clifford-algebra state nor a conditional expectation.
Proposition. Constants and odd Gaussian observables [fdip-002Y]AGENTDRAFTED
- October 25, 2026
Proposition. Constants and odd Gaussian observables [fdip-002Y]AGENTDRAFTED
- October 25, 2026
For the Gaussian expectation associated to positive self-adjoint \(Q\) on \((E,h)\), constants satisfy \(\omega _Q(c)=c\). Every absolutely integrable odd Borel function \(F\), meaning \(F(-x)=-F(x)\), has \(\omega _Q(F)=0\). In particular each linear observable \(\ell _j(x)=h(j,x)\) has mean zero.
Proof.
- October 25, 2026
Proof.
- October 25, 2026
Normalization gives the assertion for constants. Negation is an isometry and preserves canonical volume, by the orthogonal invariance argument in coordinates. Moreover \(h(-x,Q(-x))=h(x,Qx)\), so it preserves the weight. Absolute integrability makes substitution legitimate and gives \[\omega _Q(F)=\omega _Q(F\circ (-I))=-\omega _Q(F).\] Thus the expectation is zero. Linear observables are integrable by Proposition [fdip-002W]. When \(E=0\), an odd function must vanish at its unique point.
This is a direct consequence of normalization and the change-of-variables convention used in [tao2011measure, Exercise 1.2.21, p. 41, preliminary version]. Oddness alone, without absolute integrability, does not define an expectation.
Definition. Covariance and variance of Gaussian observables [fdip-002Z]AGENTDRAFTED
- October 25, 2026
Definition. Covariance and variance of Gaussian observables [fdip-002Z]AGENTDRAFTED
- October 25, 2026
Let \(\mu _Q\) be the Gaussian law on a finite real inner-product space \((E,h)\), and write \(\omega _Q\) for its expectation. For Borel \(X,Y:E\to \mathbb R\) with \(X\), \(Y\) and \(XY\) absolutely integrable, define their covariance by \[\begin {aligned} \operatorname {Cov}_Q(X,Y) &=\omega _Q(XY)-\omega _Q(X)\omega _Q(Y)\\ &=\omega _Q\bigl ((X-\omega _Q(X))(Y-\omega _Q(Y))\bigr ). \end {aligned}\] Expansion and normalization prove the second equality; all 4 terms are integrable by the stated hypotheses. This extends the finite-sum covariance to integrals.
When \(X\) and \(X^2\) are integrable, its variance is \[\begin {aligned} \operatorname {Var}_Q(X)&=\operatorname {Cov}_Q(X,X)\\ &=\omega _Q\bigl ((X-\omega _Q(X))^2\bigr )\\ &=\omega _Q(X^2)-\omega _Q(X)^2\geq 0. \end {aligned}\] The inequality is positivity of the integral. In particular all these expressions exist for polynomials by Proposition [fdip-002W], consistently with the polynomial state.
For \(\ell _j(x)=h(j,x)\), set \(K(j,k)=\operatorname {Cov}_Q(\ell _j,\ell _k)\). It is a finite symmetric bilinear form. There is a unique linear covariance operator \(C_Q:E\to E\), relative to the specified \(h\), such that \(h(j,C_Qk)=K(j,k)\).
Proof.
- October 25, 2026
Proof.
- October 25, 2026
In an orthonormal basis put \(C_Qk=\sum _i K(u_i,k)u_i\). Bilinearity of \(K\) follows from integral linearity and gives the linearity of \(C_Q\). Orthonormal expansion proves the required pairing. If \(C_Q'\) has the same pairings, then \(h(j,(C_Q-C_Q')k)=0\) for every \(j,k\); choosing \(j=(C_Q-C_Q')k\) proves equality. Thus the construction is independent of the basis. At \(E=0\) it is the unique map. This representation does not identify \(C_Q\) with inverse precision.
For the counting field space, the coordinate means vanish by Proposition [fdip-002Y], and the former coordinate notation is \[\begin {aligned} \operatorname {Cov}_Q(u,v) &=\left \langle (\phi _u-\langle \phi _u\rangle _Q) (\phi _v-\langle \phi _v\rangle _Q)\right \rangle _Q\\ &=\langle \phi _u\phi _v\rangle _Q. \end {aligned}\] The partition function, this two-point expectation, and the expectation of a different observable are different quantities. The separate inverse-precision theorem computes this covariance.
The definitions extend Notation [ftip-008H] directly; the integral identities use the preceding moment and state results. Positivity uses the ordinary real convention of [waldmann2004states, Definition 3.9, p. 11] through Definition [fdip-0024], not an additional inverse-covariance assumption.
The four-cycle covariance calculation evaluates these quantities for the running example.
Example. Integrable observables need not form an algebra [fdip-0030]AGENTDRAFTED
- October 25, 2026
Example. Integrable observables need not form an algebra [fdip-0030]AGENTDRAFTED
- October 25, 2026
Let \(Q\) be positive self-adjoint on \((E,h)\) with \(n=\dim E>0\). The Borel function \(F=e^{S_Q/2}\) is integrable under the Gaussian law, since \[\int _E Fw_Q\,d\lambda _E =\int _E e^{-S_Q/2}\,d\lambda _E=Z_{Q/2}<\infty \] by positive normalization. But \(F^2=e^{S_Q}\) is not integrable: \(F^2w_Q=1\), and \(\lambda _E(E)=\infty \). Indeed orthonormal cubes have masses \((2R)^n\) tending to infinity.
Thus actual integrable observables form a vector space but are not closed under multiplication. The same counterexample works for their almost-everywhere classes in \(L^1(\mu _Q)\). The polynomial algebra is an integrable algebra by Proposition [fdip-002W]. For \(n=0\), every real observable is constant on a singleton, so this failure is absent.
This is a direct comparison of the two normalizers, using Theorem [fdip-002T] and the scalar ingredient in Keith Conrad's [conradGaussianIntegral, Section 2, PDF pp. 1-2]; it also retains \(e^{S_Q}\) as a concrete Borel nonintegrable observable in positive dimension.
Definition. Massive graph Green functions [fdip-000A]AGENTDRAFTED
- October 16, 2026
Definition. Massive graph Green functions [fdip-000A]AGENTDRAFTED
- October 16, 2026
Let \(V\) be a finite vertex set, with positive edge weights, and let \(L\) be its weighted graph Laplacian. For \(m>0\), define the massive precision and its Green operator by \[Q_m=L+m^2I,\qquad G_m=Q_m^{-1}.\] The inverse exists even when the graph is disconnected. Indeed, the energy identity gives, for \(f\ne 0\), \[\begin {aligned} \langle f,Q_mf\rangle _V &=\sum _e w(e)(Df)(e)^2\\ &\quad +m^2\sum _v f(v)^2>0. \end {aligned}\] Thus \(Q_mf=0\) implies \(f=0\). Finite dimension and rank-nullity make this injective endomorphism surjective, so it is an isomorphism. The inverse-response lemma now gives a self-adjoint inverse and the unique solution \(f=G_mj\) to \(Q_mf=j\). The endomorphism \(Q_m\) is a positive precision parameter; its counting array realizes it as a positive symmetric matrix. For \(j\ne 0\), write \(x=G_mj\ne 0\); then \(\langle j,G_mj\rangle _V=\langle Q_mx,x\rangle _V>0\). On an empty vertex set the same map argument gives the unique isomorphism of zero modules; there are no point-source columns.
By the real spectral theorem, choose an orthonormal eigenbasis \(u_a\) of the self-adjoint operator \(L\), with eigenvalues \(\lambda _a\ge 0\). The energy identity proves this last inequality by evaluation on each unit eigenvector. Put \(q_a=\lambda _a+m^2>0\). Then \[\begin {aligned} Q_m&=\sum _a q_a u_au_a^T,\\ G_m&=\sum _a q_a^{-1}u_au_a^T. \end {aligned}\] Since \(u_a^Tu_b=\delta _{ab}\) and \(\sum _a u_au_a^T=I\), multiplication gives \(Q_mG_m=G_mQ_m=I\). Also \(G_m^T=G_m\), and \(f^TG_mf=\sum _a q_a^{-1}(u_a^Tf)^2>0\) for nonzero \(f\).
The Green kernel is defined from the inverse map by \(G_m(v,w)=(G_m\delta _w)(v)\). These are its matrix entries in the counting coordinate basis. Its column at \(w\) is the unique field solving \[Q_mG_m(\cdot ,w)=\delta _w,\] where \(\delta _w(v)\) is one at \(v=w\) and zero elsewhere. For a source field \(j\), the unique solution of \(Q_mf=j\) is \(f(v)=\sum _wG_m(v,w)j(w)\). No vertex-volume factor occurs because the vertex pairing and basis are counting.
This convention has to be matched when comparing lattice Green functions. Wingate's lattice action uses a positive operator built from minus the backward-forward difference and a mass term [wingate2025lattice, Section 4, Equations (4.2)-(4.5), p. 3]. For unit spacing, that difference term has the sign of our \(L\).
In [friedli2017statistical, Theorem 8.26, p. 399], the massive lattice precision is \[Q=-\frac {1}{2d}\Delta +m^2I.\] Here \(\Delta f(x)=\sum _{y\sim x}(f(y)-f(x))\). The factor \(1/(2d)\) and the lattice boundary conditions belong to that normalization. Identifying their covariance with an inverse requires that precision, not an unscaled adjacency Laplacian.
Mathlib's Matrix.PosDef.isUnit proves invertibility of a
positive definite matrix, and Matrix.PosDef.inv proves
positivity of its inverse. These apply to the matrix step after the
graph-energy calculation supplies positivity. The kernel convention and
its graph interpretation are specified here.
Theorem. Covariance is inverse precision [fdip-000B]AGENTDRAFTED
- October 16, 2026
Theorem. Covariance is inverse precision [fdip-000B]AGENTDRAFTED
- October 16, 2026
Let \(Q\) be a positive self-adjoint precision on a finite real inner-product space \((E,h)\), with its Gaussian law. For \(j,k\in E\), put \(\ell _j(x)=h(j,x)\). Then \[\begin {aligned} \omega _Q(\ell _j)&=0,\\ \operatorname {Cov}_{\mu _Q}(\ell _j,\ell _k) &=h(j,Q^{-1}k). \end {aligned}\] Thus its covariance operator, relative to the specified pairing, is \(C_Q=Q^{-1}\). On the counting vertex space, \(\ell _{\delta _v}(\phi )=\phi (v)\), so \[\omega _Q(\phi (v)\phi (w)) =h_V(\delta _v,Q^{-1}\delta _w).\] For \(Q=L+m^2I\), this is the Green kernel, with no vertex-volume factor. The density convention agrees with [friedli2017statistical, Proposition B.55, p. 505, and Theorem 8.4, p. 385] after substituting covariance \(Q^{-1}\) for precision \(Q\).
Proof.
- October 16, 2026
Proof.
- October 16, 2026
Write \(g_a(x)=\exp (-a x^2/2)\) and \(I(a)=\int _{\mathbb R}g_a(x)\,dx\) for \(a>0\). The scalar normalization gives \(0<I(a)<\infty \); finite polynomial moments give absolute integrability of \(xg_a(x)\) and \(x^2g_a(x)\). Reflection makes the first integral its own negative, hence zero. On \([-R,R]\), integrate \((xg_a(x))'=g_a(x)-a x^2g_a(x)\) to obtain \[\begin {aligned} a\int _{-R}^R x^2g_a(x)\,dx &=\int _{-R}^R g_a(x)\,dx\\ &\quad -2R\exp (-aR^2/2). \end {aligned}\] For \(R\geq 1\), \(e^{aR^2/2}\geq aR^2/2\) gives \(R e^{-aR^2/2}\leq 2/(aR)\to 0\). Monotone convergence on both nonnegative integrands, with their already established finite integrals, therefore gives \[I(a)^{-1}\int _{\mathbb R}x^2g_a(x)\,dx=a^{-1}.\]
Choose an orthonormal eigenbasis \(u_i\) of \(Q\), with \(Qu_i=q_i u_i\), \(q_i>0\). In \(x=\sum _i y_i u_i\), volume preservation and normalization give the product density \[\prod _i g_{q_i}(y_i)/I(q_i).\] All coordinate products are absolutely integrable by Proposition [fdip-002W], so signed Fubini applies. Integrating the other coordinates gives one. For \(i\ne j\), the two first moments give zero; for \(i=j\), the scalar second moment gives \(q_i^{-1}\). Thus \(\omega _Q(y_i y_j)=\delta _{ij}q_i^{-1}\) and every \(\omega _Q(y_i)=0\). The finite expansion \(\ell _j(x)=\sum _i h(j,u_i)y_i\) now yields \[\begin {aligned} \operatorname {Cov}(\ell _j,\ell _k) &=\sum _i q_i^{-1}h(j,u_i)h(k,u_i)\\ &=h(j,Q^{-1}k). \end {aligned}\] If two operators represented this bilinear form, their difference applied to \(k\) would be orthogonal to every \(j\), hence zero. This proves uniqueness. In dimension zero the covariance is the zero form, and its representing map is the unique invertible endomorphism.
For a nonorthonormal basis \(b_i\), the coordinate functional is \(h(b^i,\cdot )\). The dual basis satisfies \(h(b^i,b_j)=\delta _{ij}\). Its covariance array therefore has entries \(h(b^i,Q^{-1}b^j)\); it is not the unqualified array of the inverse operator in that basis. The counting basis is orthonormal, giving the coordinate formula above. The alternating-cycle example evaluates it explicitly.
To compare with formal Gaussian providers, put \(n=\dim E\), choose an orthonormal
chart and let \(S\) represent \(Q^{-1}\) there. The positive inverse
is positive definite, \(S^{-1}\) represents \(Q\), and
\(\det S=(\det Q)^{-1}\). Consequently the provider density is
\[\begin {aligned}
&(2\pi )^{-n/2}(\det S)^{-1/2}
e^{-y^TS^{-1}y/2}\\
&\qquad =Z_Q^{-1}e^{-h(x,Qx)/2}.
\end {aligned}\]
The orthonormal chart and the Euclidean-space coordinate
wrapper preserve canonical volume. Thus the chart pushforward of
\(\mu _Q\) is \(\mathrm {multivariateGaussian}(0,S)\) by
TauCeti.Probability.multivariateGaussian_eq_withDensity.
Mathlib's
ProbabilityTheory.covariance_eval_multivariateGaussian
then identifies its coordinate covariance with \(S\); its positive
semidefinite hypothesis follows from positive definiteness. The
parameter is covariance \(S=Q^{-1}\), not precision \(Q\). This density,
determinant and volume identification is needed in addition to the
covariance declaration; the integral proof above is independent of it.
Example. Exact covariance on the alternating four-cycle [fdip-0037]AGENTDRAFTED
- October 29, 2026
Example. Exact covariance on the alternating four-cycle [fdip-0037]AGENTDRAFTED
- October 29, 2026
Take the four-cycle on \(V=(0,1,2,3)\), with forward edges and weights \((1,t,1,t)\), \(t>0\). Use counting pairing and \(Q=L+m^2I\), \(m>0\). Put \(a=m^2\) and \(s=1+t+a\). The following functions on vertices form an orthonormal eigenbasis; the middle column lists the unnormalized rows \(2u_i^T\): \[\begin {array}{c|c|c} i&2u_i^T&\lambda _i\\\hline 0&(1,1,1,1)&0\\ 1&(1,-1,-1,1)&2\\ 2&(1,1,-1,-1)&2t\\ 3&(1,-1,1,-1)&2+2t \end {array}\]
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Each row has squared norm 4. Distinct rows agree in two signs and disagree in two, giving inner product zero. The weighted coordinate formula is \((L\phi )_0=(1+t)\phi _0-\phi _1-t\phi _3\), with the other rows given by their adjacent weights. For \(v_i=2u_i\), all 4 products are \[\begin {aligned} Lv_0&=(0,0,0,0),\\ Lv_1&=(2,-2,-2,2),\\ Lv_2&=(2t,2t,-2t,-2t),\\ Lv_3&=(2+2t,-2-2t,\\ &\qquad 2+2t,-2-2t). \end {aligned}\] For example the zeroth coordinates are respectively \(0\), \((1+t)+1-t=2\), \((1+t)-1+t=2t\), and \((1+t)+1+t=2+2t\); the same substitutions at the other three vertices give the displayed signs. Thus \(Lu_i=\lambda _i u_i\). This basis remains orthonormal at \(t=1\), when \(\lambda _1=\lambda _2\); no distinct-eigenvalue assumption is needed.
Set \[\begin {aligned} q_0&=a,\\ q_1&=a+2,\\ q_2&=a+2t,\\ q_3&=a+2+2t,\\ \Delta &=a(a+2)(a+2t)(a+2+2t). \end {aligned}\] All 4 \(q_i\) are positive. With \(P_{u_i}=u_i u_i^T\), normalization and inverse covariance give \[\begin {aligned} \det Q&=\Delta ,& Z_Q&=4\pi ^2/\sqrt \Delta ,\\ G&=\sum _{i=0}^3q_i^{-1}P_{u_i}. \end {aligned}\] With \(O\) the array whose columns are \(u_i\), this is \(G=O\operatorname {diag}(q_i^{-1})O^T\).
Write \(d_i=q_i^{-1}\). Multiplying the signs of the relevant coordinates in each projector gives \[\begin {aligned} 4G_{00}&=d_0+d_1+d_2+d_3,\\ 4G_{01}&=d_0-d_1+d_2-d_3,\\ 4G_{02}&=d_0-d_1-d_2+d_3,\\ 4G_{03}&=d_0+d_1-d_2-d_3. \end {aligned}\] Thus the complete covariance, with \((A,B,C,D)=(G_{00},G_{01},G_{02},G_{03})\), is \[G=\begin {pmatrix} A&B&C&D\\B&A&D&C\\C&D&A&B\\D&C&B&A \end {pmatrix}.\] In particular the variance and adjacent two-point expectation are the first two formulas, with their indicated signs.
For the opposite entry, the common denominator \(4\Delta \) has numerator \[\begin {aligned} N&=(a+2)(a+2t)(a+2+2t)\\ &\quad -a(a+2t)(a+2+2t)\\ &\quad -a(a+2)(a+2+2t)\\ &\quad +a(a+2)(a+2t)\\ &=2[(a+2t)(a+2+2t)-a(a+2)]\\ &=8t(a+1+t). \end {aligned}\] Consequently \(G_{02}=2ts/\Delta \). At \((t,m)=(1,1)\), \(q=(1,3,3,5)\), \(\Delta =45\), \(Z_Q=4\pi ^2/(3\sqrt 5)\), and \[\begin {aligned} &(G_{00},G_{01},G_{02},G_{03})\\ &\qquad =(7/15,1/5,2/15,1/5). \end {aligned}\] At \((t,m)=(2,1)\), \(q=(1,3,5,7)\), \(\Delta =105\), and \[(G_{00},G_{01},G_{02},G_{03}) =(44,19,16,26)/105.\] These numbers are obtained by direct substitution in the 4 signed sums above. They give, in particular, the opposite covariance used in block elimination and the two distinct adjacent covariances used in relabeling.
More generally, weights \((b,c,b,c)\) with \(b,c>0\) keep the same 4 eigenvectors and give eigenvalues \(0,2b,2c,2b+2c\), by the same coordinate products. This is a real spectral calculation. The arithmetic columns are \(2u_i\), whose Gram matrix is \(4I\); they are not an orthonormal basis over an arbitrary coefficient ring.
The eigenvectors and signed sums are computed here from the weighted cycle.
[boyd2004convex, Section A.5.2, pp. 646-647] gives general spectral decomposition.
[friedli2017statistical, Proposition B.55, p. 505] gives the Gaussian density. Covariance equals inverse precision by Theorem [fdip-000B].
Constrained massless Gaussian laws [fdip-003V]AGENTDRAFTED
- October 30, 2026
Constrained massless Gaussian laws [fdip-003V]AGENTDRAFTED
- October 30, 2026
Removing the mass from the four-cycle action leaves constant fields unpenalized, so the full-space integral diverges. Restricting to mean-zero fields removes this direction, but requires the subspace's own volume. The zero-mass cycle calculation gives the resulting normalizer and a finite variance for the difference of opposite field values.
The positive Gaussian law on the orthogonal complement of the kernel yields this constrained probability and its pseudoinverse covariance. Kernel factorization and projected limits distinguish the divergent full normalizer from finite difference observables. Pinning a vertex gives another constraint, with a generally different coordinate covariance; the two-vertex comparison makes the distinction explicit. These choices also matter when eliminating singular directions.
Definition. Kernel complement and pseudodeterminant [fdip-0031]AGENTDRAFTED
- October 29, 2026
Definition. Kernel complement and pseudodeterminant [fdip-0031]AGENTDRAFTED
- October 29, 2026
Let \(L:E\to E\) be a self-adjoint positive semidefinite operator on a finite real inner-product space \((E,h)\). Set \[\begin {aligned} K&=\ker L,& H&=K^\perp ,\\ k&=\dim K,& r&=\dim H. \end {aligned}\] Write \(i:H\to E\) for inclusion, \(p_H:E\to H\) for orthogonal projection, \(P_H=ip_H\) and \(P_K=I-P_H\) for the endomorphism projections.
The spectral theorem gives \(E=K\mathbin \perp H\). The positive-eigenvalue vectors span \(H\), so \(L(H)\subset H\) and \(L_H=L|_H:H\to H\) is positive definite. Define the pseudodeterminant by \[\operatorname {pdet}L=\det L_H =\prod _{\lambda _a>0}\lambda _a.\] Its empty product is one, including \(L=0\). These definitions use the specified pairing and its induced subspace volume.
For a weighted incidence Laplacian with positive real edge weights, the kernel theorem identifies \(K\) with fields constant on each connected component. Indeed its energy is a sum of positive weights times squared edge differences; zero energy means every difference is zero, and propagation along undirected paths gives those constants. Loops contribute zero and isolated vertices are components. Thus \(H\) imposes zero sum separately on each component. For a connected nonempty graph, \(n=|V|\) gives the mean-zero field space \[\begin {aligned} u_0&=\mathbf 1_V/\sqrt n,\\ H&=\{\phi :\sum _v\phi (v)=0\},\\ P_H\phi &=\phi -\frac {\sum _v\phi (v)}{n}\mathbf 1_V. \end {aligned}\] The empty graph has \(E=K=H=0\); no division by \(n\) is used there.
The kernel complement and determinant product are direct consequences of the spectral decomposition in [boyd2004convex, Section A.5.2, pp. 646-647]; the graph kernel uses the incidence-energy identity proved in Theorem [fdip-0008].
The massless four-cycle calculation makes this kernel complement and pseudodeterminant explicit.
Proposition. The Laplacian Moore-Penrose inverse [fdip-0032]AGENTDRAFTED
- October 29, 2026
Proposition. The Laplacian Moore-Penrose inverse [fdip-0032]AGENTDRAFTED
- October 29, 2026
With the kernel decomposition, define the Laplacian pseudoinverse by \[L^+=iL_H^{-1}p_H.\] This is the unique endomorphism \(A\) satisfying the 4 Moore-Penrose identities: \[\begin {aligned} LAL&=L,& ALA&=A,\\ (LA)^\dagger &=LA,&(AL)^\dagger &=AL. \end {aligned}\] It vanishes on \(K\), is the inverse of \(L_H\) on \(H\), and has spectral expression \(L^+=\sum _{\lambda _a>0}\lambda _a^{-1}P_{u_a}\), where \(P_u x=h(u,x)u\) for a unit eigenvector.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
On the orthogonal decomposition \(K\mathbin \perp H\), the operators \(L,L^+\) have blocks \((0,L_H)\) and \((0,L_H^{-1})\). Hence \[LL^+=L^+L=P_H.\] The inverse on \(H\) is self-adjoint by the inverse-response lemma. Thus \(L^+\) is self-adjoint, both products are self-adjoint, and multiplication once more gives \(LL^+L=L\) and \(L^+LL^+=L^+\).
Suppose \(A\) satisfies the 4 identities. Then \(LA\) is self-adjoint and idempotent, since \(LALA=LA\). Its range lies in \(\operatorname {ran}L=H\), and \(LAL=L\) shows it acts as the identity on \(H\). Thus it is the orthogonal projection \(P_H\). Similarly \(AL\) is self-adjoint and idempotent. Its kernel is \(K\): \(Lx=0\) implies \(ALx=0\), while \(ALx=0\) implies \(Lx=LALx=0\). A self-adjoint idempotent is the orthogonal projection onto its kernel complement, so \(AL=P_H\). For \(y=Lx\in H\), \[Ay=ALx=P_Hx=L_H^{-1}y.\] Finally \(A=ALA=A(LA)=AP_H\), so \(A\) vanishes on \(K\). These two restrictions force \(A=L^+\). The argument includes \(H=0\) and \(E=0\); the unique map on the zero space is its own inverse.
TauCeti's LinearMap.IsMoorePenroseInverse
uses exactly these 4 conditions for real inner-product spaces.
Its LinearMap.IsMoorePenroseInverse.unique
supports uniqueness, and the finite-dimensional characterization
LinearMap.isMoorePenroseInverse_iff_eq_moorePenroseInverse
identifies this construction with \(L.\mathrm {moorePenroseInverse}\).
The weaker inner-inverse identity \(LAL=L\) alone gives neither this
uniqueness nor a constrained probability law.
The construction is a direct specialization of the orthogonal spectral decomposition in [boyd2004convex, Section A.5.2, pp. 646-647]. The four-identity and uniqueness arguments above establish the additional Moore-Penrose conclusion; no Gaussian law follows from that conclusion alone.
Proposition. Massless fields with a kernel-orthogonal constraint [fdip-000C]AGENTDRAFTED
- October 16, 2026
Proposition. Massless fields with a kernel-orthogonal constraint [fdip-000C]AGENTDRAFTED
- October 16, 2026
Let \(L\) be self-adjoint positive semidefinite on a finite real inner-product space \((E,h)\), with the kernel decomposition \(K=\ker L\), \(H=K^\perp \), \(k=\dim K\), \(r=\dim H\). The induced volume \(\lambda _H\) gives the centered probability law \[\begin {aligned} Z_H&=\frac {(2\pi )^{r/2}}{\sqrt {\operatorname {pdet}L}},\\ d\nu _H(x)&=Z_H^{-1}e^{-h(x,Lx)/2}\,d\lambda _H(x). \end {aligned}\] Its pushforward to \(E\) has covariance \(L^+\). If \(k>0\), the full-space massless integral is infinite, and the restriction of ambient volume to \(H\) is zero; neither replaces this induced measure.
Proof.
- October 16, 2026
Proof.
- October 16, 2026
The operator \(L_H\) is positive definite by Definition [fdip-0031]. Apply normalization and inverse covariance on the inner-product space \(H\). The induced measure is independent of its orthonormal chart by isometric volume preservation. For ambient sources \(j,k'\in E\), restriction of their linear observables gives \[\begin {aligned} \operatorname {Cov}_{i_*\nu _H}(\ell _j,\ell _{k'}) &=h_H(p_Hj,L_H^{-1}p_Hk')\\ &=h(j,L^+k'), \end {aligned}\] using the pseudoinverse construction. Thus the ambient covariance is singular when \(K\ne 0\), although its restriction to \(H\) is an inverse.
Suppose \(k>0\). In an orthonormal chart \(H\) is \(\{0\}^k\times \mathbb R^r\). Each of its intersections with a finite box has product volume zero; a countable union of these boxes covers \(H\), proving zero ambient measure. For divergence, take a bounded box of positive induced volume in \(H\). Continuity gives the weight a strictly positive lower bound on its closure. On its product with \([-R,R]^k\subset K\), the weight is unchanged in the kernel direction, so the integral is bounded below by a positive constant times \((2R)^k\). This tends to infinity. When \(H=0\), its singleton has induced volume one, and the same argument applies.
When \(k=0\), \(H=E\) and the full-space law already exists. When \(E=0\), \(k=r=0\), both normalizers are one and the probability is Dirac. When \(L=0\) on a positive-dimensional space, \(H=0\) gives the constrained Dirac law while the full normalizer diverges. All determinant products over zero-dimensional spaces are one.
For a connected nonempty graph with positive edge weights, put \(n=|V|\). Then \(H\) is exactly the mean-zero field space, \(r=n-1\), and the formula becomes \(Z_H=(2\pi )^{(n-1)/2}/\sqrt {\prod _{a=1}^{n-1}\lambda _a}\). At \(n=1\), \(H=0\), \(Z_H=1\), and the full one-dimensional integral still diverges. With \(k>1\) components, a single global sum-zero constraint removes only one dimension of the component-constant kernel: the sum functional is nonzero on that \(k\)-dimensional space, so its kernel has dimension \(k-1\). The restricted integral still diverges by the same kernel-box argument. Componentwise zero sums remove all these modes. The empty graph uses the zero-dimensional case above.
Massive factorization gives the exact divergent factor, while projected limits identify the finite limits of polynomial and difference observables. Vertex pinning uses another constraint and generally another coordinate covariance, as the two-vertex example shows. The distinction between free and fixed-boundary massless models also appears in [friedli2017statistical, Definition 8.1, Remark 8.2 and Exercise 8.2, p. 381]; the induced-volume and finite-graph proofs here specify the present law.
Proposition. Massive kernel factorization and its normalizer [fdip-0033]AGENTDRAFTED
- October 29, 2026
Proposition. Massive kernel factorization and its normalizer [fdip-0033]AGENTDRAFTED
- October 29, 2026
Let \(L\) have the kernel decomposition and let \(m>0\). The positive precision \(Q_m=L+m^2I\) has inverse and normalizer \[\begin {aligned} Q_m^{-1}&=m^{-2}P_K\\ &\quad +i(L_H+m^2I_H)^{-1}p_H,\\ Z_{Q_m}&=(\sqrt {2\pi }/m)^k Z_{H,m},\\ Z_{H,m}&=\frac {(2\pi )^{r/2}} {\sqrt {\prod _{\lambda _a>0}(\lambda _a+m^2)}}. \end {aligned}\] Under the addition isometry \(K\times H\to E\), its probability law is the product of the centered \(K\)-law with precision \(m^2I_K\) and the centered \(H\)-law with precision \(L_H+m^2I_H\). In particular its pushforward by \(p_H\) is exactly the second law.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
On \(K\), \(Q_m=m^2I_K\); on \(H\), \(Q_m=L_H+m^2I_H\). Inverting these blocks gives the displayed inverse. The addition isometry preserves product volume, and the action splits: \[\begin {aligned} &\tfrac 12h(z+x,Q_m(z+x))\\ &\quad =\tfrac 12m^2\|z\|^2\\ &\qquad +\tfrac 12h(x,(L_H+m^2I_H)x). \end {aligned}\] Nonnegative Tonelli therefore factors the integral into the two normalizers. Positive normalization makes the first \((\sqrt {2\pi }/m)^k\) and the second the stated spectral product. Division by this product identifies the probability on every measurable rectangle with the product of the two probabilities, hence identifies the measures. Integrating out the \(K\) factor gives the projection law.
Every empty product is one. Thus these formulas hold when \(k=0\), \(r=0\), or \(E=0\). Since each positive eigenvalue stays positive, \[\begin {aligned} Z_{H,m}&\longrightarrow Z_H,\\ m^k Z_{Q_m}&\longrightarrow (2\pi )^{k/2}Z_H. \end {aligned}\] Here \(Z_H\) is the constrained normalizer. For \(k>0\), the full normalizer diverges. This is orthogonal kernel separation; it does not require a general block-elimination theorem.
This product calculation combines the orthogonal decomposition with the positive-covariance density of [friedli2017statistical, Proposition B.55, p. 505] after replacing covariance by inverse precision. The displayed kernel factor is derived here, including zero-dimensional factors.
Proposition. Projected Gaussian laws and the massless limit [fdip-0034]AGENTDRAFTED
- October 29, 2026
Proposition. Projected Gaussian laws and the massless limit [fdip-0034]AGENTDRAFTED
- October 29, 2026
For the kernel decomposition, let \(\nu _m\) be the projection onto \(H\) of the law with precision \(L+m^2I\), \(m>0\). Then \(\nu _m\) converges to the constrained law \(\nu _H\) in total variation, meaning \(\sup _{A\text { Borel}}|\nu _m(A)-\nu _H(A)|\to 0\). For every fixed polynomial \(P\) on \(H\), its expectations converge too.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
By kernel factorization, the densities on \(H\) are \(f_m=w_m/Z_{H,m}\), where \[\begin {aligned} w_m(x)&=e^{-h(x,(L_H+m^2I_H)x)/2},\\ w_0(x)&=e^{-h(x,L_Hx)/2}. \end {aligned}\] They are continuous, \(w_m\to w_0\) pointwise, and \(0\leq w_m\leq w_0\), with \(\int _H w_0=Z_H<\infty \). Dominated convergence gives \(Z_{H,m}\to Z_H>0\). For sufficiently small \(m\), \(Z_{H,m}\geq Z_H/2\); hence \[|f_m-f_0|\leq 3w_0/Z_H.\] Another application gives \(\int _H|f_m-f_0|\to 0\). For each Borel \(A\), \(|\nu _m(A)-\nu _H(A)|\leq \int _H|f_m-f_0|\), proving the uniform claim. For a fixed polynomial, the dominating function \(3|P|w_0/Z_H\) is integrable by finite polynomial moments, so \(\int P f_m\to \int P f_0\). Each use of dominated convergence applies along every positive sequence \(m_j\to 0\); the sequential criterion gives the real-parameter limits as \(m\downarrow 0\). When \(H=0\), these laws are all the same point mass.
For a fixed source \(j\in E\) and \(\ell _j(x)=h(j,x)\), the inverse-covariance formula and the kernel split give \[\begin {aligned} \operatorname {Var}_{Q_m}(\ell _j) &=m^{-2}\|P_Kj\|^2\\ &\quad +\sum _{\lambda _a>0} \frac {h(j,u_a)^2}{\lambda _a+m^2}. \end {aligned}\] Every term is nonnegative. The finite sum converges; the first term is finite in the limit precisely when \(P_Kj=0\). Thus the variance has a finite limit if and only if \(j\in H\), in which case it is \(h(j,L^+j)\).
For a connected nonempty graph with positive edge weights, put \(n=|V|\). The source \(u_0=\mathbf 1_V/\sqrt n\) has variance \(m^{-2}\) as a source. Its contribution to every Green-kernel entry is \(1/(nm^2)\), and \(G_m(v,v)\geq 1/(nm^2)\). A field difference has source \(\delta _v-\delta _w\in H\), so its variance converges to the constrained variance. On a disconnected graph this holds for vertices in the same component; a difference between components has a nonzero kernel projection. These observable limits do not supply a normalized full-space massless density.
The analytic ingredient is [tao2011measure, Theorem 1.4.49, pp. 111-112, preliminary version]. The three dominators above verify its hypotheses for these Gaussian laws and their fixed polynomial observables.
Proposition. Pinned affine massless laws [fdip-0035]AGENTDRAFTED
- October 29, 2026
Proposition. Pinned affine massless laws [fdip-0035]AGENTDRAFTED
- October 29, 2026
Let a finite nonempty graph be connected, with positive edge weights. Put \(n=|V|\) and fix a vertex \(p\). Its massless action defines a probability law on \(F_p=\{\phi :\phi (p)=0\}\) with induced counting volume. For any \(b\in \mathbb R\), translation by \(b\mathbf 1_V\) defines the law on the affine constraint \(\phi (p)=b\); its mean is \(b\mathbf 1_V\) and its covariance is that of the zero-pinned law.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Write \(i_F:F_p\to \mathbb R^V\) for inclusion and \(p_F:\mathbb R^V\to F_p\) for orthogonal projection. The compressed precision is \[Q_F=p_F L i_F:F_p\to F_p.\] It is self-adjoint, since \(h_F(x,Q_Fy)=h_V(i_Fx,Li_Fy)\). A zero-energy vector is constant by the kernel theorem; vanishing at \(p\) makes it zero. Thus \(Q_F\) is positive definite. Normalization on the inner-product space \(F_p\) gives \[Z_F=(2\pi )^{(n-1)/2}/\sqrt {\det Q_F}.\] The centered law has covariance \(Q_F^{-1}\) on \(F_p\), and ambient covariance \(i_F Q_F^{-1}p_F\), by Theorem [fdip-000B]. The subspace need not be invariant under \(L\); the precision is the compressed quadratic form, not an endomorphism restriction of \(L\).
The affine constraint equals \(b\mathbf 1_V+F_p\). Define its induced volume by translating the volume on \(F_p\). Since \(D(b\mathbf 1_V+\psi )=D\psi \), this translation preserves the action and normalizer. Centeredness on \(F_p\) gives the stated mean; subtracting that mean gives exactly the zero-pinned covariance. For a single vertex \(F_p=0\), the normalizer is one and the law is concentrated at the value \(b\).
These are laws on their own constraint spaces. They are not defined by conditioning on an event in an unconstrained massless probability, whose normalizer diverges. Fixed external boundary values also remove zero modes in finite lattice regions, as in [friedli2017statistical, Definition 8.1, Remark 8.2 and Exercise 8.2, p. 381]. That source's lattice boundary and volume conventions remain part of its model; the induced-volume construction here proves the finite-graph claim.
Example. Pinning and mean zero on two vertices [fdip-0036]AGENTDRAFTED
- October 29, 2026
Example. Pinning and mean zero on two vertices [fdip-0036]AGENTDRAFTED
- October 29, 2026
Join vertices \(0,1\) by one edge of weight \(w>0\). In counting coordinates its Laplacian is \[L=w\begin {pmatrix}1&-1\\-1&1\end {pmatrix}.\] The unit mean-zero vector \(u=(1,-1)/\sqrt 2\) has eigenvalue \(2w\). Thus the mean-zero law has \[\begin {aligned} Z_H&=\sqrt {2\pi }/\sqrt {2w},\\ L^+&=\frac 1{4w}\begin {pmatrix}1&-1\\-1&1\end {pmatrix}. \end {aligned}\] The factor \(1/\sqrt 2\) is required because the reference measure is the induced orthonormal volume on \(H\).
Pinning \(\phi _0=0\) leaves the unit vector \(\delta _1\); its action is \(w\phi _1^2/2\). The pinned law therefore has \[\begin {aligned} Z_F&=\sqrt {2\pi }/\sqrt w,\\ C_F&=\begin {pmatrix}0&0\\0&1/w\end {pmatrix}. \end {aligned}\] These ambient coordinate covariances differ. But for the difference \(\phi _0-\phi _1\), applying the two covariance forms to \((1,-1)\) gives \(1/w\) in both cases. This agreement of one observable does not identify the laws. For a single vertex the zero-pinned and mean-zero spaces are both zero, so that special case has no such distinction.
These are direct one-dimensional Gaussian calculations using the positive density in [friedli2017statistical, Proposition B.55, p. 505] and the two explicitly specified induced volumes.
Example. The alternating cycle at zero mass [fdip-0038]AGENTDRAFTED
- October 29, 2026
Example. The alternating cycle at zero mass [fdip-0038]AGENTDRAFTED
- October 29, 2026
The alternating-cycle eigenbasis has constant unit vector \(u_0=(1,1,1,1)/2\); its positive eigenvalues are \(2,2t,2+2t\). Hence the mean-zero law has \[\begin {aligned} \operatorname {pdet}L&=8t(1+t),\\ Z_H&=\frac {(2\pi )^{3/2}}{\sqrt {8t(1+t)}},\\ L^+&=\tfrac 12P_{u_1}+\tfrac 1{2t}P_{u_2} +\tfrac 1{2+2t}P_{u_3}. \end {aligned}\] Its covariance rows follow from the 4 signed sums of Example [fdip-0037] by setting \(d_0=0\), \(d_1=1/2\), \(d_2=1/(2t)\), and \(d_3=1/(2+2t)\). This is the pseudoinverse, not an inverse on the full vertex space.
At \(t=1\), its first row is \[(5/16,-1/16,-3/16,-1/16).\] All diagonal entries are \(5/16\). Thus an opposite field difference has variance \(2(5/16)-2(-3/16)=1\), while an adjacent difference has variance \(2(5/16)-2(-1/16)=3/4\). Both are finite limits of the corresponding massive variances by Proposition [fdip-0034].
The massive constant contribution to every covariance entry is \(1/(4m^2)\). Its divergence cancels in field differences, and kernel factorization gives the exact normalizer relation \[\begin {aligned} Z_{Q_m}&=\frac {\sqrt {2\pi }}{m}Z_{H,m},\\ mZ_{Q_m}&\longrightarrow \sqrt {2\pi }Z_H. \end {aligned}\] The full normalizer therefore does not tend to \(Z_H\); the constrained law uses its own three-dimensional reference volume.
This calculation applies the induced-volume construction of Proposition [fdip-000C] to the positive spectral modes.
[friedli2017statistical, Proposition B.55, p. 505] supplies the positive Gaussian density. The zero-mode removal and its normalization factor are derived above.
Elimination and retained observables [fdip-0018]AGENTDRAFTED
- October 20, 2026
Elimination and retained observables [fdip-0018]AGENTDRAFTED
- October 20, 2026
Eliminating selected real field values produces both a new quadratic action and a normalization factor. The prerequisites are a positive quadratic action, its normalized Gaussian law, and the reference measure and orthogonal product volume. Inverse precision first determines covariance; averaging out the discarded variables gives retained precision equal to the Schur complement \(S\), with covariance operator \(S^{-1}\) for the specified inner product.
For integrable observables of the retained variables, retained expectation agrees with original expectation after pullback. The planned states and conditional expectations chapter asks how such averaging fits a common language of observables and states. Opposite vertices of the four-cycle make the normalization and covariance explicit. The conditional kernel distinguishes fixing variables from averaging them, while singular eliminated directions explain when the integration space itself must change.
For a formal quartic perturbation, successive Gaussian eliminations agree with direct elimination through second order in the coupling. The three-coordinate example displays the generated terms and a retained connected four-point function; stationary elimination distinguishes the tree contribution from fluctuation terms.
Theorem. Eliminating a positive Gaussian block [fdip-000D]AGENTDRAFTED
- October 17, 2026
Theorem. Eliminating a positive Gaussian block [fdip-000D]AGENTDRAFTED
- October 17, 2026
Let \(E=X\mathbin \perp Y\) be a specified orthogonal sum of finite-dimensional real inner-product spaces. Write \(h_E,h_X,h_Y\) for their pairings, \(i_X,i_Y\) for inclusion and \(p_X,p_Y\) for orthogonal projection. The addition isometry is \(J(x,y)=i_Xx+i_Yy\). Use canonical Euclidean volume on uncompleted Borel sets. Then product volume gives \(J_*(\lambda _X\otimes \lambda _Y)=\lambda _E\). Zero summands are allowed; their volume is unit mass on a singleton.
Let \(Q:E\to E\) be a self-adjoint positive precision parameter. Its components for this splitting are \[\begin {aligned} A&=p_XQi_X:X\to X,\\ B&=p_XQi_Y:Y\to X,\\ C&=p_YQi_Y:Y\to Y. \end {aligned}\] The fourth component is \(p_YQi_X=B^\dagger \), where the adjoint uses the specified pairings. Both \(C\) and the effective precision, or real Schur complement, \[S=A-BC^{-1}B^\dagger :X\to X\] are positive definite and invertible. This is the real positive specialization of the split Schur map.
Put \(w_Q(z)=\exp (-h_E(z,Qz)/2)\) and \(q=\dim Y\). For every \(x\in X\), the exact fiber integral is \[\begin {aligned} I_Q(x)&=\int _Y w_Q(J(x,y))\,d\lambda _Y(y)\\ &=c_C\exp (-h_X(x,Sx)/2),\\ c_C&=\frac {(2\pi )^{q/2}}{\sqrt {\det C}}=Z_C>0. \end {aligned}\] Moreover \(\det Q=\det C\det S\). Thus elimination induces both \(S\) and a positive finite scalar \(c_C\).
Proof.
- October 17, 2026
Proof.
- October 17, 2026
Positivity under elimination applies to these real inner products. Explicitly, testing \(Q\) on \(i_Yy\) gives \(C>0\); finite dimension makes \(C\) invertible. Put \(K=C^{-1}B^\dagger \). The orthogonal congruence identity is \[\begin {aligned} &h_E(J(x,y),QJ(x,y))\\ &\quad =h_X(x,Sx)\\ &\qquad +h_Y(y+Kx,C(y+Kx)). \end {aligned}\] Indeed \(CK=B^\dagger \) and \(K^\dagger =BC^{-1}\); expansion cancels the term subtracted in \(S\). The self-adjoint inverse of \(C\) makes \(S\) self-adjoint. For \(x\ne 0\), testing on \(J(x,-Kx)\ne 0\) gives \(h_X(x,Sx)>0\).
For fixed \(x\), translation by \(Kx\) preserves reference volume. Square completion and positive Gaussian normalization therefore give \[\begin {aligned} I_Q(x)&=e^{-h_X(x,Sx)/2} \int _Y e^{-h_Y(v,Cv)/2}\,d\lambda _Y(v)\\ &=e^{-h_X(x,Sx)/2}Z_C. \end {aligned}\] This is a nonnegative integral with a positive finite prefactor; no signed Fubini interchange is needed. The same square completion shows that the stationary field is \(y_*(x)=-Kx\). Minimization alone does not evaluate the fiber integral or its scalar.
For the determinant, let \(V(x,y)=(x,y+Kx)\) and \(D(x,y)=(Sx,Cy)\) on \(X\oplus Y\). Congruence gives \(J^{-1}QJ=V^\dagger DV\). Choose bases \(e_1,\ldots ,e_p\) of \(X\) and \(f_1,\ldots ,f_q\) of \(Y\), with the same ordered concatenation in domain and codomain. In the top wedge of the images under \(V\), we have \(Ve_j=e_j+Ke_j\) and \(Vf_k=f_k\). Any term choosing some \(Ke_j\) has more than \(q\) vectors in \(Y\), so it vanishes. The remaining term is the original top wedge; hence \(\det V=1\). In orthonormal coordinates, the adjoint is the transpose and has the same determinant, by reindexing the determinant permutation sum. The direct sum \(D\) acts on the top wedge by \(\det S\det C\). Multiplicativity of this scalar and invariance under conjugation now prove \(\det Q=\det C\det S\). Empty bases give determinant one, so the argument includes zero summands.
Taking minus the logarithm of the positive fiber integral defines an exact effective action: \[\begin {aligned} \mathcal A_{\mathrm {eff}}(x) &=\tfrac 12h_X(x,Sx)-\log c_C\\ &=\tfrac 12h_X(x,Sx)+\tfrac 12\log \det C\\ &\quad -\tfrac q2\log (2\pi ). \end {aligned}\] The constant cancels from normalized retained expectations but belongs to the unnormalized weight. Rescaling the two reference volumes by \(a_X,a_Y>0\) multiplies \(c_C\) by \(a_Y\), \(Z_S\) by \(a_X\) and \(Z_Q\) by \(a_Xa_Y\); normalized laws remain unchanged. For \(Y=0\), \(c_C=1\); for \(X=0\), \(Z_S=1\). In each case the unique zero-space endomorphism is invertible and has determinant one.
For counting fields on \(V=R\sqcup U\), the delta bases identify \(X=\mathbb R^R\), \(Y=\mathbb R^U\), \(B=H\) and \(B^\dagger =H^T\). Coordinate volume splitting recovers the usual \(dx\,dy\) formula. The carrier, split, input precision and volumes are supplied; \((S,c_C)\) is induced relative to those choices. The singular-pivot boundary requires a separate argument.
[boyd2004convex, Appendix A.5.5, pp. 650-651] gives square completion with the first block as pivot. Exchanging its order to \((y,x)\) gives the present eliminated pivot \(C\).
[rasmussen2006gaussian, Appendix A.2, equation (A.4), p. 200] gives the Gaussian density with covariance as parameter. Substituting \(C^{-1}\) gives the normalizer used here. The invariant integration and determinant argument above reconstruct these ingredients with specified pairings and volume.
Mathlib's Matrix.schur_complement_eq₂₂ supports square
completion in compatible finite coordinates, with a Hermitian
invertible eliminated block. Its Matrix.det_fromBlocks₂₂
supports the determinant identity. TauCeti's
Matrix.PosDef.gaussianCondCov supports strict Schur
positivity for a real positive-definite block matrix. Despite its
conditional-covariance name, this algebraic conclusion can be applied
to the precision \(Q\). These ingredients do not supply the integral
or its reference-volume convention.
The operation is algebraic: it acts on vertex and edge sets that are supplied, and carries neither a dynamical carrier nor an effective metric, which are additional data.
Theorem. The retained Gaussian marginal [fdip-000E]AGENTDRAFTED
- October 17, 2026
Theorem. The retained Gaussian marginal [fdip-000E]AGENTDRAFTED
- October 17, 2026
Use the orthogonal sum \(E=X\mathbin \perp Y\), positive precision \(Q\), effective precision \(S\) and exact scalar \(c_C\) of Gaussian elimination. Let \(\pi =p_X:E\to X\) and let \(\mu _Q,\mu _S\) be the independently defined Gaussian probability laws. Then \[Z_Q=c_CZ_S,\qquad \pi _*\mu _Q=\mu _S.\] Thus the retained marginal law is \(\mu _S\): for every Borel \(D\subseteq X\), \(\mu _Q(\pi ^{-1}D)=\mu _S(D)\). Here pushforward assigns \(D\) the mass of its inverse image, extending the finite pushforward convention to these Borel spaces.
Every real Borel function \(F:X\to \mathbb R\) satisfies the extended nonnegative identity \[\int _E|F\circ \pi |\,d\mu _Q =\int _X|F|\,d\mu _S\ \in [0,\infty ].\] Consequently \(F\in L^1(\mu _S)\) if and only if \(F\circ \pi \in L^1(\mu _Q)\). Under these equivalent conditions, \[\int _E F\circ \pi \,d\mu _Q=\int _X F\,d\mu _S.\] We use actual Borel functions; \(L^1\) here denotes their integrable vector space. It is not asserted to be an algebra.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The projection is linear, hence continuous and Borel. The weights are continuous and nonnegative, and the orthogonal product volumes are sigma-finite. Nonnegative Tonelli and the fiber formula give \[\begin {aligned} Z_Q&=\int _X\int _Y w_Q(J(x,y))\,d\lambda _Y(y)\,d\lambda _X(x)\\ &=c_C\int _X e^{-h_X(x,Sx)/2}\,d\lambda _X(x)\\ &=c_CZ_S. \end {aligned}\] All three factors are positive and finite by normalization. This also agrees with \(\det Q=\det C\det S\).
For a Borel set \(D\), repeat Tonelli with the nonnegative factor \(\mathbf 1_D(x)\). Division by \(Z_Q=c_CZ_S\) gives \[\begin {aligned} \mu _Q(\pi ^{-1}D) &=\frac {c_C}{Z_Q}\int _D e^{-h_X(x,Sx)/2}\,d\lambda _X(x)\\ &=\mu _S(D). \end {aligned}\] This proves equality of measures without inferring it from second moments.
Repeat the same calculation with \(|F(x)|\). Nonnegative Tonelli allows the value infinity, so it proves the asserted absolute-integral identity before any integrability assumption. If these absolute integrals are finite, signed Fubini applies. Equivalently, repeat the nonnegative calculation for \(F^+\) and \(F^-\) and subtract their finite integrals. This proves the signed expectation equality.
For a finite real vector space \(W\), write \(\mathcal P(W)\) for its intrinsic polynomial function algebra, generated by linear functionals. The actual map on observables is \[\begin {aligned} \pi ^*:\mathcal P(X)&\longrightarrow \mathcal P(E),\\ P&\longmapsto P\circ \pi . \end {aligned}\] It is an injective unital real algebra homomorphism preserving the identity involutions. For the Gaussian polynomial states, \[\omega _S=\omega _Q\circ \pi ^*.\] The field projection goes \(E\to X\); this observable inclusion goes in the opposite direction.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
A linear functional on \(X\) pulls back to a linear functional on \(E\), so composition preserves the polynomial algebras. Pointwise evaluation proves preservation of sums, products, real scalar multiples and the constant one. Both involutions are the identity. Since \(\pi i_X=I_X\), equality \(P\circ \pi =R\circ \pi \) composed with \(i_X\) implies \(P=R\). This is the invariant form of polynomial pullback, with the actual section \(i_X\).
Every polynomial, product and square is absolutely integrable by Proposition [fdip-002W]. Thus \(\omega _Q(P)=\int P\,d\mu _Q\) and \(\omega _S(P)=\int P\,d\mu _S\) are independently defined real Hermitian positive normalized functionals: they are linear, take one to one, respect the identity star and take \(P^*P=P^2\) to a nonnegative number. Apply the expectation identity to each \(P\) to obtain \(\omega _S(P)=\omega _Q(\pi ^*P)\). Abstract state pullback guarantees that the right side is a state; the integral calculation identifies which Gaussian state it is. No conditional expectation, partial trace or state on field endomorphisms has been introduced.
The inverse-compression and covariance identities are \[\begin {aligned} p_XQ^{-1}i_X&=S^{-1},\\ \operatorname {Cov}_{\mu _Q}(\ell _j\circ \pi ,\ell _k\circ \pi ) &=h_X(j,S^{-1}k), \end {aligned}\] where \(\ell _j(x)=h_X(j,x)\). The means vanish. In counting coordinates this is \((Q^{-1})_{RR}=S^{-1}\).
Proof.
- October 17, 2026
Proof.
- October 17, 2026
To check inverse compression directly, solve \(QJ(u,v)=i_Xb\). Its lower component gives \(v=-C^{-1}B^\dagger u\); its upper gives \(Su=b\). Hence \(u=S^{-1}b=p_XQ^{-1}i_Xb\). The existence of \(C^{-1}\) uses positivity, not merely invertibility of the whole \(Q\).
Orthogonality gives \(\ell _j\pi (z)=h_E(i_Xj,z)\). Inverse-precision covariance and \(i_X^\dagger =p_X\) then give the claimed covariance and zero means. Alternatively use the expectation equality for \(\ell _j,\ell _k\) and their product. These functions are integrable polynomials. For a nonorthonormal basis, coordinate functionals have their own Riesz representatives; their covariance array is not an unqualified array of the inverse operator.
Fixing the eliminated field is a different operation from averaging it. The conditional-law calculation gives its parameters; the four-cycle comparison exhibits a difference even when the fixed value is zero.
[rasmussen2006gaussian, Appendix A.2, equations (A.5)-(A.6), p. 200] gives Gaussian marginal and conditional parameters. The inverse block formula is in [rasmussen2006gaussian, Appendix A.3, equation (A.13), p. 202]. Its joint parameter is covariance \(\Sigma =Q^{-1}\). Retained covariance is therefore \(p_X\Sigma i_X=S^{-1}\), not \(S\).
In orthonormal coordinates, \(\Sigma ^{-1}=Q\) and
\(\det \Sigma =(\det Q)^{-1}\) turn the provider density into
\(Z_Q^{-1}w_Q\); the density and volume comparison
identifies the probability laws. Mathlib's
ProbabilityTheory.measurePreserving_restrict₂_multivariateGaussian
then supports coordinate restriction with covariance \(\Sigma \).
TauCeti's TauCeti.Probability.map_affine_multivariateGaussian
supports rectangular affine images with positive-semidefinite
covariance. Apply its linear map as the orthonormal presentation of
\(p_X\) and its translation as zero. These concern Gaussian
probability measures, not volume preservation by a projection.
Mathlib's MeasureTheory.integral_prod supports signed
Fubini under integrability. None of these declarations supplies the
raw factor \(c_C\) or removes the preceding absolute-value argument.
Proposition. An explicit conditional Gaussian kernel [fdip-003A]AGENTDRAFTED
- October 29, 2026
Proposition. An explicit conditional Gaussian kernel [fdip-003A]AGENTDRAFTED
- October 29, 2026
In the orthogonal positive setting of Gaussian elimination, let \(X\) be retained and \(Y\) eliminated. The components of \(Q\) are \(A,B,B^\dagger ,C\). Put \(T=C-B^\dagger A^{-1}B\) and \(c_A=(2\pi )^{\dim X/2}/\sqrt {\det A}\). The maps \(A,T\) are positive definite by exchanging the eliminated summand. For every \(y\in Y\), define a probability measure on \(X\) by \[\begin {aligned} &k_y(x)=c_A^{-1}\exp \bigl (-\tfrac 12\\ &\qquad \cdot h_X(x+A^{-1}By,A(x+A^{-1}By))\bigr ),\\ &\kappa (y,D)=\int _D k_y(x)\,d\lambda _X(x) \end {aligned}\] for Borel \(D\subseteq X\). These measures form a measurable conditional probability kernel for the retained field given the eliminated field. Its mean is \(-A^{-1}By\) and covariance operator is \(A^{-1}\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Exchanged square completion gives \[\begin {aligned} &h_E(J(x,y),QJ(x,y))\\ &\quad =h_X(x+A^{-1}By,A(x+A^{-1}By))\\ &\qquad +h_Y(y,Ty). \end {aligned}\] The joint density relative to \(\lambda _X\otimes \lambda _Y\) is \(p_Q(x,y)=Z_Q^{-1}w_Q(J(x,y))\). Its \(Y\)-marginal density is \[\begin {aligned} r(y)&=\int _Xp_Q(x,y)\,d\lambda _X(x)\\ &=\frac {c_A}{Z_Q}e^{-h_Y(y,Ty)/2}>0. \end {aligned}\] It is continuous, finite and integrates to one by Tonelli.
Division gives \(k_y(x)=p_Q(x,y)/r(y)\). Translation invariance and positive normalization prove \(\int _Xk_y\,d\lambda _X=1\) for every \(y\), including zero-dimensional spaces. Thus \(\kappa (y,\cdot )\) is a probability measure.
For fixed Borel \(D\), the function \((y,x)\mapsto \mathbf 1_D(x)k_y(x)\) is nonnegative Borel. Measurability of parameter integrals for sigma-finite volume shows that \(y\mapsto \kappa (y,D)\) is Borel. This is the measurable-parameter part of [tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version], applied to the uncompleted Borel product.
For Borel \(D\subseteq X\) and \(H\subseteq Y\), Tonelli and \(k_yr=p_Q\) give \[\mu _Q(J(D\times H)) =\int _H\kappa (y,D)r(y)\,d\lambda _Y(y).\] The set on the left is Borel because \(J\) is a homeomorphism. This rectangle identity is the conditional-distribution identity with respect to the actual \(Y\)-marginal. It divides densities, not the probability of the event \(Y=y\); in positive dimension the latter singleton has probability zero. Our version is defined for every \(y\), whereas conditional distributions in general are identified only almost everywhere.
Under \(\kappa (y,\cdot )\), the translated variable \(u=x+A^{-1}By\) has centered precision \(A\). Its mean is zero and its covariance is \(A^{-1}\) by Theorem [fdip-000B]. Translating back proves the stated mean and covariance.
The retained marginal instead has mean zero and covariance \(S^{-1}\) for \(S=A-BC^{-1}B^\dagger \). At \(y=0\), the conditional precision is \(A\), not \(S\). If \(B=0\), then \(S=A\) and the conditional mean is zero for every \(y\), so the laws coincide. The four-cycle exhibits their different off-diagonal covariances when the coupling is nonzero.
To compare covariance parameters, put \(\Sigma =Q^{-1}\) and write its components as \(\Sigma _{XX},\Sigma _{XY},\Sigma _{YY}\). The opposite-pivot inverse formulas give \[\begin {aligned} \Sigma _{YY}&=T^{-1},\\ \Sigma _{XY}&=-A^{-1}BT^{-1},\\ \Sigma _{XX}&=A^{-1}+A^{-1}BT^{-1}B^\dagger A^{-1}. \end {aligned}\] Consequently \[\begin {aligned} \Sigma _{XY}\Sigma _{YY}^{-1}&=-A^{-1}B,\\ \Sigma _{XX}-\Sigma _{XY}\Sigma _{YY}^{-1}\Sigma _{YX}&=A^{-1}. \end {aligned}\] The covariance Schur complement for conditioning differs from the precision Schur complement for marginalization.
[rasmussen2006gaussian, Appendix A.2, equation (A.6), p. 200] gives these conditional Gaussian parameters. The density construction above additionally checks normalization, parameter measurability and the conditional integral identity.
TauCeti's
TauCeti.Probability.condDistrib_multivariateGaussian
identifies a conditional distribution with its Gaussian kernel almost
everywhere for the conditioning marginal, assuming a Gaussian joint
law, positive-semidefinite covariance and a positive-definite
conditioning covariance block. Here \(\Sigma =Q^{-1}>0\) and
\(\Sigma _{YY}=T^{-1}>0\); the displayed identities supply the parameter
conversion. The totalized Gaussian constructor or a Markov-kernel
instance alone would not identify the conditional distribution.
Proposition. Singular eliminated directions and changed reference volume [fdip-0039]AGENTDRAFTED
- October 29, 2026
Proposition. Singular eliminated directions and changed reference volume [fdip-0039]AGENTDRAFTED
- October 29, 2026
Use the orthogonal spaces and components of Gaussian elimination, but assume only \(Q=Q^\dagger \geq 0\). Then \(C\geq 0\). If \(N=\ker C\ne 0\), every full fiber integral is infinite: \[\int _Y e^{-h_E(J(x,y),QJ(x,y))/2}\,d\lambda _Y(y)=\infty .\] Replacing \(C^{-1}\) by a pseudoinverse does not change that integral.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
For \(z\in N\), \(x\in X\) and every real \(r\), positivity gives \[0\leq h_X(x,Ax)+2r h_X(x,Bz).\] An affine real function bounded below for all \(r\) has slope zero. Thus \(h_X(x,Bz)=0\) for every \(x\); taking \(x=Bz\) gives \(Bz=0\). Adjointness consequently gives \(B^\dagger X\subseteq N^\perp \). The weight at \(J(x,z+y_0)\) is independent of \(z\in N\).
Put \(Y_0=N^\perp \). Choose a compact orthonormal unit box \(D\subseteq Y_0\) of positive finite induced volume. If \(Y_0=0\), use its singleton of mass one. For fixed \(x\), the continuous strictly positive weight has a minimum \(\epsilon _x>0\) on \(D\). With \(k=\dim N>0\), integrate over the product of \(D\) and the orthonormal box \([-R,R]^k\subseteq N\). Product volume gives the lower bound \(\epsilon _x\lambda _{Y_0}(D)(2R)^k\). It tends to infinity. This proves divergence without multiplying an unexplained infinite constant by an integral.
For example, on \(X=Y=\mathbb R\), \(Q(x,y)=(x,0)\) has weight \(e^{-x^2/2}\), independent of \(y\). Thus \(e^{-x^2/2}\int _{\mathbb R}dy=\infty \) for every \(x\).
A different model integrates only over \(Y_0\) with its induced Euclidean volume. Let \(j_0:Y_0\to Y\) and \(p_0:Y\to Y_0\) be orthogonal inclusion and projection. The restriction \(C_0=C|_{Y_0}\) is positive definite, and the Moore-Penrose construction is \[C^+=j_0C_0^{-1}p_0.\] For \(r=\dim Y_0=\operatorname {rank}C\), put \[\begin {aligned} S_0&=A-BC^+B^\dagger ,\\ c_0&=\frac {(2\pi )^{r/2}}{\sqrt {\operatorname {pdet}C}}. \end {aligned}\] Then \(S_0\geq 0\) and \[\begin {aligned} &\int _{Y_0}e^{-h_E(J(x,j_0y),QJ(x,j_0y))/2}\,d\lambda _{Y_0}(y)\\ &\qquad =c_0e^{-h_X(x,S_0x)/2}. \end {aligned}\] A normalized law on the full retained \(X\) exists exactly when \(S_0>0\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Self-adjointness makes \(Y_0\) invariant under \(C\). Its spectral decomposition shows that \(Y_0\) is the sum of positive eigenspaces; hence \(C_0>0\). Its determinant is \(\operatorname {pdet}C\), including the empty product one. Since \(B^\dagger X\subseteq Y_0\), put \(K_0=C_0^{-1}p_0B^\dagger \). The same expansion as in square completion gives \[\begin {aligned} &h_E(J(x,j_0y),QJ(x,j_0y))\\ &\qquad =h_X(x,S_0x)\\ &\qquad \quad +h_{Y_0}(y+K_0x,C_0(y+K_0x)). \end {aligned}\] Testing \(y=-K_0x\) proves \(S_0\geq 0\). Translation invariance on \(Y_0\) and positive normalization give the stated changed-space integral. If \(S_0>0\), a further Gaussian integral on \(X\) is finite. If \(S_0\) has a nonzero kernel, the same box argument proves divergence there. A finite-dimensional positive semidefinite self-adjoint map without a kernel is positive definite, so these exhaust the possibilities.
In rank zero, \(C=0\), \(B=0\), \(Y_0=0\), \(C^+=0\), \(\operatorname {pdet}C=1\), \(c_0=1\) and \(S_0=A\). Integration over \(Y_0\) is evaluation on its unit-mass singleton. When \(X=0\), its retained normalizer is one. These conventions cover the zero spaces without restricting ambient Lebesgue measure to a lower-dimensional subspace.
The singular positive-semidefinite pivot, its range condition and pseudoinverse quadratic minimum are treated in [boyd2004convex, Appendix A.5.5, p. 651]. Exchanging the pivot gives the algebra used here. The divergence and induced-volume calculation above are additional arguments. The constrained Gaussian construction likewise changes the space and measure. Neither a general indefinite pivot nor a regularized value for the original divergent fiber is asserted.
Example. Eliminating alternate vertices of the four-cycle [fdip-000F]AGENTDRAFTED
- October 17, 2026
Example. Eliminating alternate vertices of the four-cycle [fdip-000F]AGENTDRAFTED
- October 17, 2026
In the alternating four-cycle, take \(t,m>0\) and \(Q=Q_{t,m}=L_t+m^2I\). Its counting-pairing energy is \[\begin {aligned} &\langle \phi ,Q\phi \rangle \\ &\quad =(\phi _1-\phi _0)^2+t(\phi _2-\phi _1)^2\\ &\qquad +(\phi _3-\phi _2)^2+t(\phi _0-\phi _3)^2\\ &\qquad +m^2\sum _v\phi _v^2. \end {aligned}\] It is positive for every nonzero field. Retain \(R=(0,2)\) and eliminate \(U=(1,3)\), with coordinates \(x=(\phi _0,\phi _2)\) and \(y=(\phi _1,\phi _3)\) in these orders. The maps \(x\mapsto x_0\delta _0+x_2\delta _2\) and \(y\mapsto y_1\delta _1+y_3\delta _3\) are isometries from ordinary \(\mathbb R^2\); their sum is the specified orthogonal splitting, and product volume is \(dx\,dy\). Write \(a=m^2\) and \(s=1+t+a\). Reordering the explicit Laplacian gives \[\begin {aligned} A=C&=sI_2,\\ B=H&=-\begin {pmatrix}1&t\\t&1\end {pmatrix}. \end {aligned}\] The elimination theorem therefore gives \[\begin {aligned} S&=\begin {pmatrix}\alpha &-\beta \\-\beta &\alpha \end {pmatrix},\\ \alpha &=s-\frac {1+t^2}{s},\qquad \beta =\frac {2t}{s}>0. \end {aligned}\] Indeed \(HH^T\) has diagonal \(1+t^2\) and off-diagonal \(2t\), so \(S=sI_2-s^{-1}HH^T\).
[boyd2004convex, Appendix A.5.5], pp. 650-651, gives the general Schur complement. Here the chosen blocks make its entries explicit.
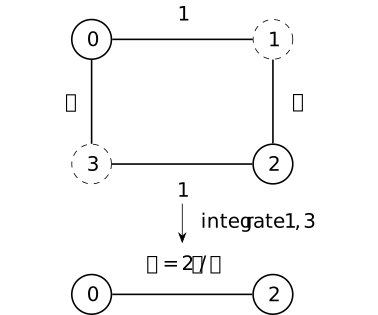
Solid circles are retained; dashed circles are integrated out. Orientations are suppressed because the quadratic energy is orientation independent. The bottom edge represents the induced coupling \(\beta \); its precision also has the diagonal term computed below.
The vectors \((1,1)^T/\sqrt 2\) and \((1,-1)^T/\sqrt 2\) diagonalize \(S\). Their eigenvalues are \[\begin {aligned} \sigma _+&=\alpha -\beta =\frac {s^2-(1+t)^2}{s}\\ &=\frac {a(a+2+2t)}{s},\\ \sigma _-&=\alpha +\beta =\frac {s^2-(1-t)^2}{s}\\ &=\frac {(a+2)(a+2t)}{s}. \end {aligned}\] Both are positive. The factorizations follow from \(s=1+t+a\); they also check positivity without appealing again to the general theorem. Put \[\mathcal D=a(a+2)(a+2t)(a+2+2t).\] Then \[\begin {aligned} \det C&=s^2,\qquad \det S=\mathcal D/s^2,\\ \det Q&=\det C\det S=\mathcal D,\\ c_C&=\frac {2\pi }{s},\qquad Z_S=\frac {2\pi s}{\sqrt {\mathcal D}},\\ Z_Q&=c_CZ_S=\frac {(2\pi )^2}{\sqrt {\mathcal D}}. \end {aligned}\] This reproduces the four-mode determinant and partition function. The effective action is \[\mathcal A_{\mathrm {eff}}(x)=\tfrac 12x^TSx+\log \frac {s}{2\pi }.\] Its constant records the integrated block.
A retained observable checks more than normalization. For \(F(x)=x_0x_2\), polynomial integrability and the marginal identity give \[\begin {aligned} \langle \phi _0\phi _2\rangle _Q &=\langle x_0x_2\rangle _S =(S^{-1})_{02}\\ &=\frac {\beta }{\alpha ^2-\beta ^2} =\frac {2ts}{\mathcal D}. \end {aligned}\] The indices \(0,2\) here name retained vertices. Inverting the displayed two-by-two matrix gives its off-diagonal entry \(\frac {\beta }{\det S}\), which proves the last equalities. Independently, the four-cycle spectral table gives \[\begin {aligned} 4\langle \phi _0\phi _2\rangle _Q &=\frac 1a-\frac 1{a+2}\\ &\quad -\frac 1{a+2t}+\frac 1{a+2+2t}\\ &=\frac {8ts}{\mathcal D}. \end {aligned}\] For the last equality, pair the first two terms and the last two: their difference has numerator \(2((a+2t)(a+2+2t)-a(a+2))=8ts\) over \(\mathcal D\). At \(t=m=1\), one obtains \[\begin {aligned} S&=\begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix},\\ S^{-1}&=\frac 1{15}\begin {pmatrix}7&2\\2&7\end {pmatrix},\\ \langle \phi _0\phi _2\rangle _Q&=\frac {2}{15},\\ c_C&=\frac {2\pi }{3},\quad Z_S=\frac {2\pi }{\sqrt 5},\quad Z_Q=\frac {4\pi ^2}{3\sqrt 5}. \end {aligned}\] Fixing the eliminated fields to zero instead gives precision \(A=3I_2\), covariance \(I_2/3\) and zero off-diagonal covariance. At \(t=2,m=1\), the same formulas give \[\begin {aligned} S&=\begin {pmatrix}11/4&-1\\-1&11/4\end {pmatrix},\\ \det S&=105/16,\\ S^{-1}&=\frac 1{105}\begin {pmatrix}44&16\\16&44\end {pmatrix}. \end {aligned}\] These are the parameters used in the symmetry comparison.
In the orthonormal sector coordinates \(x_\pm =(x_0\pm x_2)/\sqrt 2\) and \(y_\pm =(y_1\pm y_3)/\sqrt 2\), the couplings are \(-(1+t)\) and \(-(1-t)\). Their two eliminated pivots are both \(s\); each contributes \(\sqrt {2\pi/s}\), whose product is \(2\pi/s\). The factors \(1/\sqrt 2\) make these changes orthogonal, so there is no extra volume factor. The retained variance is \(\frac 12(\sigma _+^{-1}+\sigma _-^{-1})\), and the opposite covariance is \(\frac 12(\sigma _+^{-1}-\sigma _-^{-1})\). This agrees with the sector calculation.
There was no edge between vertices \(0\) and \(2\) in the supplied cycle. Elimination induces one in the effective quadratic form: \[S=\beta \begin {pmatrix}1&-1\\-1&1\end {pmatrix} +\sigma _+I_2.\] Thus \(\beta \) is an effective edge weight and \(\sigma _+\) an effective mass coefficient. This is a finite instance of fill-in: eliminating a single vertex joined to retained vertices with weights \(w_i\) and diagonal precision \(c>0\) subtracts \(ww^T/c\), creating off-diagonal entries \(-w_iw_j/c\) where no retained edge existed. The formula is the same Schur complement with \(H=-w\) and \(C=(c)\). Locality in the original graph need not survive elimination.
The half-turn preserves both sets \(R,U\) and swaps the two coordinates within each. For the swap matrix \(J\), the displayed \(S\) satisfies \(JSJ=S\); the induced two-site form retains this symmetry. The density and orthogonal-volume invariance then show that the retained law is invariant as well.
At \(m=0\), \(C=(1+t)I_2\) remains positive. Square completion and integration over the eliminated block still give \[S=\frac {2t}{1+t}\begin {pmatrix}1&-1\\-1&1\end {pmatrix}, \qquad c_C=\frac {2\pi }{1+t}.\] The retained constant mode has zero energy, so its full integral diverges by the kernel-box argument. The finite fiber factor cannot be divided by a finite retained partition function.
The global mean-zero law instead uses the space \(H=\{\phi :\sum _v\phi _v=0\}\) with its own induced volume. Its constraint \(x_0+x_2+y_1+y_3=0\) couples the two parts; \(H\) is neither their unrestricted product nor the product of their separate mean-zero lines. At \(t=1\), write a field in the three positive orthonormal modes as \(\phi =z_1u_1+z_2u_2+z_3u_3\). The coordinates are independent centered Gaussians of precisions \(2,2,4\). Put \[r=\frac {z_1+z_2}{\sqrt 2},\qquad v=\frac {z_1-z_2}{\sqrt 2}.\] This orthogonal change preserves \(z_1^2+z_2^2=r^2+v^2\) and two-dimensional volume. Thus \(r,v,z_3\) still have independent centered Gaussian laws of precisions \(2,2,4\). The retained unit coordinates satisfy \[\begin {aligned} x_-&=(\phi _0-\phi _2)/\sqrt 2=r,\\ x_+&=(\phi _0+\phi _2)/\sqrt 2=z_3/\sqrt 2. \end {aligned}\] Integrating the normalized \(v\) factor and changing variable \(z_3=\sqrt 2x_+\) give independent retained Gaussian densities of precisions \(2\) and \(8\). This density calculation identifies the law, not merely its covariance. Returning orthogonally to \((x_0,x_2)\) gives \[\begin {aligned} \operatorname {Cov}(x)&=\frac 1{16} \begin {pmatrix}5&-3\\-3&5\end {pmatrix},\\ Q_{H\to R}&=\begin {pmatrix}5&3\\3&5\end {pmatrix}. \end {aligned}\] These matrices multiply to the identity. The projected normalizer for this precision is \(\frac {2\pi }{\sqrt {16}}=\frac \pi 2\).
In contrast, directly setting \(m=0,t=1\) in the Schur formula gives the singular precision \(\begin {pmatrix}1&-1\\-1&1\end {pmatrix}\). Separately constraining that retained model to \(x_0+x_2=0\) leaves unit direction \((1,-1)/\sqrt 2\) with precision \(2\), normalizer \(\sqrt \pi \) and ambient covariance \(\frac 14\begin {pmatrix}1&-1\\-1&1\end {pmatrix}\). These are three distinct specified measures. The pinned affine law is another constraint with its own induced volume; fixing a vertex is not the marginal operation above.
The arithmetic pivot boundary is separate from the positive-real case. At \(m^2=1,t=-2\), \(s=t+2=0\), whereas \(\det Q=1\cdot 3\cdot (-3)\cdot (-1)=9\). Thus the full map can be invertible while this eliminated pivot is not. At \(t=-1\), the pivot exists but the later ratio denominator \(t+1\) vanishes. Neither value satisfies the positive-weight hypotheses used for the Gaussian laws here.
Proposition. Formal interaction under Gaussian elimination [fdip-0046]AGENTDRAFTED
- October 30, 2026
Proposition. Formal interaction under Gaussian elimination [fdip-0046]AGENTDRAFTED
- October 30, 2026
Eliminating a field with a quartic interaction generally creates quadratic and sextic terms. The coefficients through second order can be found by conditional Gaussian moments, while preserving a supplied symmetry and composition of eliminations.
Use the finite orthogonal sum \(E=X\mathbin \perp Y\), positive precision \(Q\), components \(A,B,C\), Schur precision \(S\) and scalar \(c_C\) of Gaussian elimination. Let \(T:E^4\to \mathbb R\) be a symmetric four-linear form and put \[V(u)=\frac {T(u,u,u,u)}{4!}.\] Write \(\mathcal P(X)\) for the polynomial function algebra. For \(x\in X\), let \(\eta \) have centered Gaussian law with covariance \(C^{-1}\) on \(Y\), and set \[v_x=(x,-C^{-1}B^\dagger x+\eta ).\] This is the conditional law of the eliminated field given the retained value. It is the conditional kernel with its two named summands exchanged; its covariance is \(C^{-1}\), whereas that proposition's retained-given-eliminated kernel has covariance \(A^{-1}\).
For a formal variable \(\lambda \), use ordinary power-series coefficients in \(\lambda \) and define the fiber effective interaction by \[\begin {aligned} F_\lambda (x)&=-\log \mathbb E_\eta e^{-\lambda V(v_x)},\\ \mathbb E_\eta e^{-\lambda V(v_x)} &=\sum _{n\geq 0}\frac {(-\lambda )^n}{n!} \mathbb E_\eta V(v_x)^n. \end {aligned}\] These are formal series in \(\lambda \) with coefficients in \(\mathcal P(X)\); the logarithm is the formal logarithm of a series with constant coefficient one. Every coefficient is finite by polynomial integrability. The notation \(O(\lambda ^3)\) means a series divisible by \(\lambda ^3\), not an analytic error estimate. With \[\begin {aligned} a(x)&=\mathbb E[V\mid x],\\ b(x)&=\mathbb E[V^2\mid x]-a(x)^2, \end {aligned}\] the first two coefficients are \[F_\lambda =\lambda a-\frac {\lambda ^2}{2}b+O(\lambda ^3).\] The degree-zero terms are retained: coefficientwise integration gives \[\begin {aligned} &\int _Y e^{-\frac 12\langle (x,y),Q(x,y)\rangle } e^{-\lambda V(x,y)}\,dy\\ &\qquad =c_Ce^{-\frac 12\langle x,Sx\rangle }e^{-F_\lambda (x)}. \end {aligned}\] Here \(dy\) is the specified Euclidean volume. This fiber logarithm integrates eliminated variables; it does not take the Legendre transform of a source-generating function used for a one-particle irreducible (1PI) effective action in [etingof2024mathematical, v2, Proposition 3.23, p. 50].
For a specified orthogonal flag \(E=X\mathbin \perp Y\mathbin \perp Z\), first eliminate \(Z\) and then \(Y\). All conditional expectations below use the original Gaussian law, with the \(Y\)-given-\(X\) kernel obtained after eliminating \(Z\). Put \[\begin {aligned} a_1(x,y)&=\mathbb E[V\mid x,y],\\ b_1(x,y)&=\mathbb E[V^2\mid x,y]-a_1(x,y)^2. \end {aligned}\] Both stages together give \[\begin {aligned} F_\lambda (x) ={}&\lambda \mathbb E[a_1\mid x]\\ &-\frac {\lambda ^2}{2}\bigl ( \mathbb E[b_1\mid x]+\operatorname {Var}(a_1\mid x)\bigr )\\ &+O(\lambda ^3), \end {aligned}\] which agrees with direct elimination of \(Y\oplus Z\). The first coefficient has degrees among \(4,2,0\); the second has degrees among \(6,4,2,0\). Particular components may vanish.
Proof.
- October 30, 2026
Proof.
- October 30, 2026
Expand the expectation as \(1-\lambda a+\lambda ^2\mathbb E[V^2\mid x]/2+O(\lambda ^3)\). The identity \(\log (1+u)=u-u^2/2+O(u^3)\) gives the displayed coefficient \(-b/2\). Square completion in Theorem [fdip-000D] identifies the normalized conditional Gaussian and the raw scalar \(c_C\); applying it to each polynomial coefficient proves the fiber identity. No convergence or interchange of an infinite series and an integral is needed.
The first-stage interaction is \(F_1=\lambda a_1-\lambda ^2b_1/2+O(\lambda ^3)\). Hence \[e^{-F_1}=1-\lambda a_1+ \frac {\lambda ^2}{2}(a_1^2+b_1)+O(\lambda ^3).\] Take the \(Y\)-given-\(X\) expectation and the negative logarithm. This yields the stated two-stage formula. Polynomial integrability permits signed Fubini for every coefficient, so the tower identities for these Gaussian kernels give \[\begin {aligned} &\mathbb E[a_1\mid x]=\mathbb E[V\mid x],\\ &\mathbb E[b_1\mid x]+\operatorname {Var}(a_1\mid x)\\ &\qquad =\mathbb E[V^2\mid x]-\mathbb E[V\mid x]^2. \end {aligned}\] These identities also follow directly by expanding \(b_1\) and cancelling \(\mathbb E[a_1^2\mid x]\). They prove composition through the stated order without discarding any generated term.
The mean of \(v_x\) is linear in \(x\), and its centered noise is independent of \(x\). Expanding the four-linear tensor and pairing centered Gaussian factors by Wick's theorem leaves degrees \(4,2,0\) in \(a\). In \(\mathbb E[V^2\mid x]-\mathbb E[V\mid x]^2\), pairings with no contraction between the two copies of \(V\) cancel. Every remaining pairing uses at least two noise factors. The 8 original factors therefore leave at most 6 mean factors. An even number of noise factors is paired, giving only degrees \(6,4,2,0\). The homogeneous components are symmetric tensors on \(X\) by polarization; they need not be diagonal in a chosen coordinate basis.
Suppose a second such model is related by a linear isometric isomorphism \(L=L_X\oplus L_Y:E\to E'\) satisfying \(Q'L=LQ\) and \(V'\circ L=V\). Then \[F'_\lambda (L_Xx)=F_\lambda (x)\pmod {\lambda ^3}.\] Indeed the component identities give \(C'L_Y=L_YC\) and \((B')^\dagger L_X=L_YB^\dagger \). Thus \(L_Y\) transports the conditional mean and covariance, hence its Gaussian law and both moments \(a,b\). For two-stage elimination also require preservation of the supplied flag. In particular, a supplied finite group of these isometries preserves each induced coefficient. The result transports a given action; it does not select that action.
Wick contractions are [etingof2024mathematical, v2, Theorem 3.1 and Example 3.2, p. 29]. The perturbation convention in [etingof2024mathematical, v2, Section 3.3, p. 33] is \(B(u,u)/2-\sum _i g_iB_i(u,\ldots ,u)/i!\); here \(g_4=-\lambda \) and \(B_4=T\), at \(\hbar =1\). The conditional formulas and composition above are direct deductions using these contractions and the specified Gaussian kernels. The three-coordinate example exhibits every indicated degree.
Example. A quartic interaction and its retained four-point function [fdip-0047]AGENTDRAFTED
- October 30, 2026
Example. A quartic interaction and its retained four-point function [fdip-0047]AGENTDRAFTED
- October 30, 2026
On the real realization of \(\mathbb Q^3\), use coordinates \(x,y,z\), counting pairing \(g_0=I\) and the coordinate flag retaining \((x,y)\) and then \(x\). Fix the action \(q/2+\lambda V\), where \[\begin {aligned} q&=x^2+(y-x)^2+(z-y)^2,\\ V&=\frac {x^4+y^4+z^4}{4!},\\ Q&=\begin {pmatrix}2&-1&0\\-1&2&-1\\0&-1&1\end {pmatrix},\\ Q^{-1}&=\begin {pmatrix}1&1&1\\1&2&2\\1&2&3\end {pmatrix}. \end {aligned}\] The quadratic form is positive: the map \((x,y,z)\mapsto (x,y-x,z-y)\) is invertible. The fourth tensor of \(V\) has diagonal components one and all other components zero, with the displayed \(1/4!\) convention. Simultaneous sign reversal supplies an action of \(C_2\) preserving the pairing, action and flag.
For the fiber interaction after eliminating \(y,z\), the retained precision is \(S=1\), the scalar is \(c_C=2\pi \), and \[\begin {aligned} F_\lambda (x) ={}&\lambda \left (\frac {x^4}{8}+\frac {3x^2}{4}+\frac 58\right )\\ &-\lambda ^2\left (\frac {5x^6}{72}+\frac {53x^4}{48}\right .\\ &\hspace {38pt}\left .+\frac {97x^2}{24}+\frac {41}{24}\right ) +O(\lambda ^3). \end {aligned}\] In particular, a pure quartic interaction is not preserved by elimination. Adding a quadratic term and a constant still does not close this family: the second-order sextic coefficient is nonzero.
Proof.
- October 30, 2026
Proof.
- October 30, 2026
Under the Gaussian law conditional on \(x\), write \(y=x+\eta \) and \(z=x+\eta +\xi \), where \(\eta ,\xi \) are independent standard real Gaussians. This follows directly from \(q=x^2+\eta ^2+\xi ^2\) and the triangular change of variables of determinant one. Thus \[C^{-1}=\begin {pmatrix}1&1\\1&2\end {pmatrix}, \qquad S=1,\qquad c_C=2\pi .\] With \(a=\mathbb E[V\mid x]\) and \(b=\operatorname {Var}(V\mid x)\), use \(\mathbb E\eta ^{2k}=(2k-1)!!\), with \((-1)!!=1\), and zero odd moments. The first moments are \[\begin {aligned} \mathbb E[y^4\mid x]&=x^4+6x^2+3,\\ \mathbb E[z^4\mid x]&=x^4+12x^2+12. \end {aligned}\] For the second coefficient, the same pairings give \[\begin {aligned} \operatorname {Var}(y^4\mid x) &=16x^6+168x^4\\ &\quad +384x^2+96,\\ \operatorname {Var}(z^4\mid x) &=32x^6+672x^4\\ &\quad +3072x^2+1536,\\ \operatorname {Cov}(y^4,z^4\mid x) &=16x^6+216x^4\\ &\quad +600x^2+168. \end {aligned}\] For instance these mixed moments use \(\mathbb E\eta ^2=1\), \(\mathbb E(\eta +\xi )^2=2\) and \(\mathbb E[\eta (\eta +\xi )]=1\). The term \(x^4\) is constant at fixed \(x\), so \[\begin {aligned} a&=\frac {x^4}{8}+\frac {3x^2}{4}+\frac 58,\\ b&=\frac {5x^6}{36}+\frac {53x^4}{24} +\frac {97x^2}{12}+\frac {41}{12}. \end {aligned}\] Substitute these into \(F_\lambda =\lambda a-\lambda ^2b/2+O(\lambda ^3)\).
The same coefficients arise in two stages. First eliminate \(z=y+\xi \) with \(x,y\) fixed. The moments above, with \(x\) replaced by \(y\), give \[\begin {aligned} a_1(x,y)&=\frac {x^4+2y^4+6y^2+3}{24},\\ b_1(x,y)&=\frac {y^6}{36}+\frac {7y^4}{24} +\frac {2y^2}{3}+\frac 16. \end {aligned}\] Here \(a_1=\mathbb E[V\mid x,y]\) and \(b_1=\operatorname {Var}(V\mid x,y)\); the terms \(x^4,y^4\) are constant at this stage. Next take \(y=x+\eta \). The even moments \(1,3,15,105\) of orders \(2,4,6,8\) give \[\begin {aligned} \mathbb E[a_1\mid x]&=\frac {x^4}{8}+\frac {3x^2}{4}+\frac 58=a,\\ \mathbb E[b_1\mid x]&=\frac {x^6}{36}+\frac {17x^4}{24} +\frac {11x^2}{3}+\frac {17}{8},\\ \operatorname {Var}(a_1\mid x)&=\frac {x^6}{9}+\frac {3x^4}{2} +\frac {53x^2}{12}+\frac {31}{24}. \end {aligned}\] The last two lines sum to \(b\). Thus the two-stage identity reproduces both direct coefficients, including their constants.
A source on a retained space \(X\) is a linear functional \(j\in X^*\), coupled by multiplying the weight by \(e^{j(x)}\). Under a retained linear isomorphism \(L_X:X\to X'\), a source \(j'\in (X')^*\) pulls back to \(j'\circ L_X\), since \(e^{j'(L_Xx)}=e^{(j'\circ L_X)(x)}\). In this example \(X=\mathbb R\) and \(j(x)=Jx\), with \(J\) treated as a formal scalar variable. Let \(\mu _Q\) be the normalized Gaussian law. Define \[\begin {aligned} W(J,\lambda ) ={}&\log \mathbb E_{\mu _Q}e^{Jx-\lambda V}\\ &-\log \mathbb E_{\mu _Q}e^{-\lambda V}. \end {aligned}\] Each coefficient in the two formal variables \(J,\lambda \) is a finite Gaussian moment. Thus \(W(0,\lambda )=0\). Coefficients use ordinary powers of \(\lambda \); 4 source derivatives multiply the coefficient of \(J^4\) by \(4!\). The connected four-point function in this scalar example is \[\begin {aligned} G_c^{(4)}(\lambda ) &=\left .\frac {\partial ^4W}{\partial J^4}\right |_{J=0}\\ &=-3\lambda +101\lambda ^2+O(\lambda ^3). \end {aligned}\]
Proof.
- October 30, 2026
Proof.
- October 30, 2026
Write \[\mathbb E_\lambda [P]= \frac {\mathbb E_{\mu _Q}[P e^{-\lambda V}]} {\mathbb E_{\mu _Q}e^{-\lambda V}}\] as a formal ratio. After eliminating \(y,z\), both numerator and denominator are expectations for \(x\sim N(0,1)\) with weight \[\begin {aligned} e^{-F_\lambda (x)}={}&1-\lambda a(x)\\ &+\frac {\lambda ^2}{2}(a(x)^2+b(x))\\ &+O(\lambda ^3). \end {aligned}\] The scalar \(c_C\) cancels from this ratio, but the constant terms in \(a,b\) are included before the division. Gaussian moments give \[\begin {aligned} \mathbb E[e^{-F_\lambda }]&= 1-\frac 74\lambda +\frac {1351}{96}\lambda ^2+O(\lambda ^3),\\ \mathbb E[x^2e^{-F_\lambda }]&= 1-\frac {19}{4}\lambda +\frac {1981}{32}\lambda ^2+O(\lambda ^3),\\ \mathbb E[x^4e^{-F_\lambda }]&= 3-\frac {105}{4}\lambda +\frac {14799}{32}\lambda ^2\\ &\qquad +O(\lambda ^3). \end {aligned}\] Dividing yields \[\begin {aligned} \mathbb E_\lambda [x^2]&= 1-3\lambda +\frac {511}{12}\lambda ^2+O(\lambda ^3),\\ \mathbb E_\lambda [x^4]&= 3-21\lambda +\frac {767}{2}\lambda ^2+O(\lambda ^3). \end {aligned}\] Sign reversal makes the odd moments zero and \(W(-J,\lambda )=W(J,\lambda )\). Expanding the logarithm in \(J\) therefore gives \[G_c^{(4)}=\mathbb E_\lambda [x^4] -3\bigl (\mathbb E_\lambda [x^2]\bigr )^2,\] which is the asserted coefficient.
These are formal expansions. For real \(\lambda \geq 0\), the original interaction is nonnegative, so its exact partition integral is positive and bounded by the Gaussian normalizer. Polynomial moments remain finite. A real source also gives a finite integral, since the linear tilt of a positive Gaussian is integrable. None of this asserts convergence of the formal series at zero. For every fixed \(\lambda >0\), exponentiating only the displayed second-order \(F_\lambda \) instead gives a nonintegrable retained weight: its leading term is \(-5\lambda ^2x^6/72\), so \(e^{-x^2/2-F_\lambda ^{(2)}(x)}\) grows at infinity. Here \(F_\lambda ^{(2)}\) denotes the displayed polynomial through \(\lambda ^2\).
The Gaussian moment rule is [etingof2024mathematical, v2, Theorem 3.1, p. 29]. The connected-logarithm interpretation is [etingof2024mathematical, v2, Theorem 3.11, p. 38], with \(g_4=-\lambda \) and the zero-source logarithm subtracted. The rational coefficients above are the explicit calculation for this supplied model. Stationary elimination retains its sextic term but omits the fluctuation-generated lower degrees.
Remark. Stationary elimination and the tree contribution [fdip-0048]AGENTDRAFTED
- October 30, 2026
Remark. Stationary elimination and the tree contribution [fdip-0048]AGENTDRAFTED
- October 30, 2026
For the three-coordinate quartic action, formal power-series stationarity around the Gaussian stationary point and integration of the eliminated fluctuations agree on some coefficients but not all. Write \(u=(y,z)\), \(u_0=(x,x)\) and \[H=C^{-1}=\begin {pmatrix}1&1\\1&2\end {pmatrix}.\] At fixed \(x\), the action is \[\begin {aligned} \mathcal A(x,u)={}&\frac {x^2}{2} +\frac 12(u-u_0)^TC(u-u_0)\\ &+\lambda V(x,u). \end {aligned}\] There is a unique formal stationary solution \(u_*(x,\lambda )=u_0+O(\lambda )\). Its stationary value is \[\begin {aligned} \mathcal A_{\mathrm {cl}}(x,\lambda ) &=\mathcal A(x,u_*(x,\lambda ))\\ &=\frac {x^2}{2}+\frac {\lambda x^4}{8} -\frac {5\lambda ^2x^6}{72}+O(\lambda ^3). \end {aligned}\] For real \(\lambda \geq 0\), the action is coercive and strictly convex in \(u\): the quadratic Hessian \(C\) is positive definite and the quartic summands are convex. It therefore has a unique minimizer. The calculation below uses only formal power-series stationarity around \(u_0\) at \(\lambda =0\).
Proof.
- October 30, 2026
Proof.
- October 30, 2026
The equation is \(C(u-u_0)+\lambda \nabla _uV(x,u)=0\). Since \(C\) is invertible, comparison of successive powers of \(\lambda \) uniquely determines the formal coefficients. Put \[r=\nabla _uV(x,u_0)=\frac {x^3}{6}\binom {1}{1}.\] The first coefficient gives \(u_*=u_0-\lambda Hr+O(\lambda ^2)\). Substitution in the action yields \[\mathcal A_{\mathrm {cl}}= \frac {x^2}{2}+\lambda V(x,u_0) -\frac {\lambda ^2}{2}r^THr+O(\lambda ^3).\] Now \(V(x,u_0)=x^4/8\) and \(r^THr=5x^6/36\). This proves the stationary coefficient without replacing a Gaussian integral by a minimum.
To distinguish fluctuation terms, take \(\hbar >0\), let \(\eta _\hbar \) be centered Gaussian with covariance \(\hbar H\), and use the normalized fiber expression \[\begin {aligned} &F_{\lambda ,\hbar }(x)\\ &\quad =-\hbar \log \mathbb E\exp \left ( -\frac {\lambda }{\hbar }V(x,u_0+\eta _\hbar )\right ). \end {aligned}\] Expand formally in \(\lambda \); through the second order its coefficients are polynomials in \(\hbar \): \[\begin {aligned} F_{\lambda ,\hbar }(x) ={}&\lambda \left (\frac {x^4}{8}+\frac {3\hbar x^2}{4} +\frac {5\hbar ^2}{8}\right )\\ &-\lambda ^2\left (\frac {5x^6}{72} +\frac {53\hbar x^4}{48}\right .\\ &\hspace {38pt}\left .+\frac {97\hbar ^2x^2}{24} +\frac {41\hbar ^3}{24}\right )\\ &+O(\lambda ^3). \end {aligned}\] Indeed each Gaussian pairing contributes one \(\hbar \); the first coefficient is \(\mathbb E V\) and the second is \(-\operatorname {Var}(V)/(2\hbar )\). Applying this scaling to the explicit moment calculation proves the formula.
Consequently, through order \(\lambda ^2\), the coefficient of \(\hbar ^0\) in this fiber interaction is \[\begin {aligned} [\hbar ^0]F_{\lambda ,\hbar }(x) &=\frac {\lambda x^4}{8}-\frac {5\lambda ^2x^6}{72} +O(\lambda ^3)\\ &=\mathcal A_{\mathrm {cl}}(x,\lambda )-\frac {x^2}{2} +O(\lambda ^3). \end {aligned}\] The retained Gaussian action \(x^2/2\) must be added to recover the full stationary value. At \(\lambda =0\) the normalized fiber interaction is zero, whereas that stationary value is \(x^2/2\).
This is the tree contribution in the loop grading of [etingof2024mathematical, v2, Section 3.6 and Theorem 3.12, pp. 38-39]. We adapt Etingof's rescaled convention to the displayed weight \(\exp (-\lambda V/\hbar )\) with covariance \(\hbar H\): a Gaussian contraction contributes \(\hbar \) and an interaction vertex contributes \(\hbar ^{-1}\). The logarithm selects connected graphs; after multiplication by \(-\hbar \), a connected graph with \(e\) contracted edges and \(v\) interaction vertices has power \(\hbar ^{e-v+1}\). Its number of independent cycles is \(e-v+1\); zero cycles means a tree. Thus connected contractions need not be trees. In the displayed second-order coefficient, only the sextic term is at tree order; its quartic, quadratic and constant companions have positive powers of \(\hbar \). The source's stationary-action convention is applied to the shifted fiber action, whose unperturbed minimum is zero, which explains the subtraction of \(x^2/2\).
The retained law still refers to chosen field coordinates and a chosen split. Which changes merely relabel and transport this model, and which change its predictions?
Backgrounds and symmetry [fdip-0019]AGENTDRAFTED
- October 20, 2026
Backgrounds and symmetry [fdip-0019]AGENTDRAFTED
- October 20, 2026
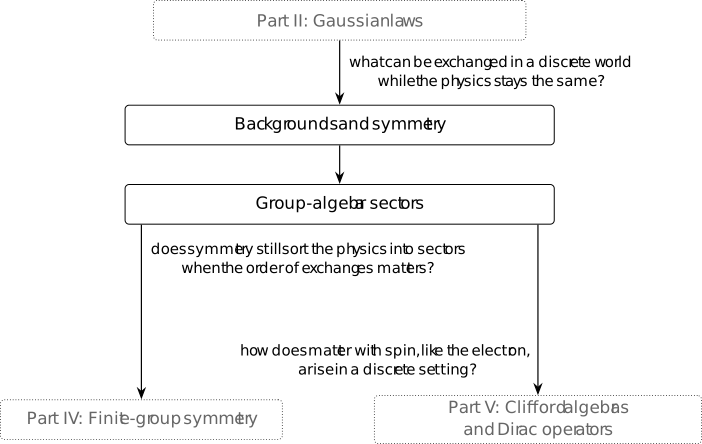
Which changes preserve the model while transporting its equations, expectations and retained law? A symmetry preserves the specified data; it transports observables rather than fixing every observable function individually. Relabellings of a finite carrier are discrete permutations, although finite-dimensional field fibres can also admit continuous internal actions. Here endpoint transport, coherent edge reversals and preserved weights control incidence and operator transport; the half-turn of the alternating cycle gives a concrete action. With compatible perfect pairings and transport of the chosen retained split, the observable functionals and marginal transport as well. The duality, split-map and normalized-functional conventions are assumed.
A finite background records the supplied data. The Gaussian integral and marginal theorem identify transported functionals with normalized laws. Fixed labels, broken weights and nonstable partitions give different failures. The trace ratio distinguishes weighted cycles even under a broader comparison allowing positive scaling. These examples prepare enriched-background comparisons, where the permitted arrows must specify exactly what survives.
Definition. Signed arrows preserve endpoints before incidence [fdip-003B]AGENTDRAFTED
- October 29, 2026
Definition. Signed arrows preserve endpoints before incidence [fdip-003B]AGENTDRAFTED
- October 29, 2026
Reversing an oriented edge changes the sign of its difference, but does not erase its endpoints. Fix a commutative unital ring \(k\) and two finite incidence presentations \((V,E,s,h)\) and \((V',E',s',h')\). Equip them with weights \(w:E\to k\), \(w':E'\to k\), scalars \(\mu ,\mu '\in k\), and retained subsets \(R\subseteq V\), \(R'\subseteq V'\). Empty carriers, loops and distinct parallel edge labels are allowed.
Write \(C_2=\{+,-\}\) for the abstract group with \(-\cdot -=+\), and \(\sigma :C_2\to k^\times \) for \(\sigma (+)=1\), \(\sigma (-)=-1\). A signed endpoint arrow consists of bijections \(p:V\to V'\), \(q:E\to E'\) and signs \(\varepsilon :E\to C_2\) such that \[\begin {aligned} \varepsilon (e)=+&:\quad s'q(e)=ps(e),\quad h'q(e)=ph(e),\\ \varepsilon (e)=-&:\quad s'q(e)=ph(e),\quad h'q(e)=ps(e),\\ w'q&=w,\qquad \mu '=\mu ,\qquad pR=R'. \end {aligned}\] The signs are abstract orientation data, even when \(1=-1\) in \(k\). An arrow with all signs \(+\) is directed. For the real Gaussian backgrounds, directed arrows are their exact relabelings, with \(\mu =m^2\); positivity of mass then recovers \(m'=m\).
Composition applies the right arrow first. The composite with \((p',q',\varepsilon ')\) is \[\bigl (p'p,q'q,\ e\mapsto \varepsilon '(q(e))\varepsilon (e)\bigr ).\] Identity arrows have identity bijections and all signs \(+\). The inverse of \((p,q,\varepsilon )\) has bijections \(p^{-1},q^{-1}\) and the sign \(\varepsilon (e)\) at \(q(e)\). These operations make the declared objects and arrows a groupoid: composition is associative, identities exist, and every arrow is invertible, as for an action groupoid.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
For two arrows, zero, one or two endpoint exchanges occur according as their signs are \((+,+)\), \((+,-)\) or \((-,+)\), and \((-,-)\). These give, respectively, the product signs \(+,-,+\). Thus composition has the required endpoints. Also \(w''q'q=w'q=w\) and \(p'pR=p'R'=R''\); the scalar stays fixed. The inverse applies the same sign twice, so restores endpoints and gives sign \(+\). For three arrows either parenthesization gives the sign \[\varepsilon ''(q'q(e))\varepsilon '(q(e))\varepsilon (e).\] Associativity in \(C_2\) and of the bijections proves associativity; the stated identities and inverses satisfy both unit and inverse laws.
Let \(M=k^V\), \(N=k^E\) and similarly \(M',N'\), with incidence maps \((df)(e)=f(h(e))-f(s(e))\). The induced ordinary linear maps are \[\begin {aligned} (Pf)(p(v))&=f(v),&P&:M\to M',\\ (Ja)(q(e))&=\sigma (\varepsilon (e))a(e),&J&:N\to N'. \end {aligned}\] They are isomorphisms: \(P^{-1}f'=f'\circ p\) and \((J^{-1}a')(e)=\sigma (\varepsilon (e))a'(q(e))\). Evaluation at \(q(e)\), in the two endpoint cases, gives \[d'P=Jd:M\longrightarrow N'.\] Both differences vanish on a loop; the endpoint condition still remembers where that loop is attached.
For a left action of a group \(\Gamma \), take actions \(p_g,q_g\) on the vertex and edge sets. A signed endpoint action additionally requires \[\varepsilon _1(e)=+,\qquad \varepsilon _{gk}(e)=\varepsilon _g(q_k(e))\varepsilon _k(e).\] Thus the arrow assigned to \(gk\) is the composite of those assigned to \(g\) and \(k\). The induced maps satisfy \(P_gP_k=P_{gk}\) and \(J_gJ_k=J_{gk}\). Indeed evaluation at \(p_{gk}(v)\) gives \(f(v)\) on both sides of the first equation; at \(q_{gk}(e)\) the second has coefficient \(\sigma (\varepsilon _g(q_k(e)))\sigma (\varepsilon _k(e))a(e)\). Identity signs and maps give the identity operators. These are linear representations on two distinct carriers; no faithfulness is assumed.
A weaker signed-incidence symmetry requires the same actions, abstract sign cocycle and weight preservation, but only the incidence equation \(dP_g=J_gd\), instead of the endpoint equations. It is an incidence intertwiner and suffices for operator transport. It need not be a graph automorphism; loops and characteristic two distinguish the requirements. The concrete half-turn satisfies the stronger endpoint conditions.
The left-action and equivariance conventions are [milne2025group, Definition 4.1, pp. 57-58]. [milne2025group, Example 7.1(b), p. 101] gives a permutation representation over a field; the ring and signed endpoint construction above is proved directly. The incidence convention in [spielman2009effective, Section 2.1, pp. 4-5] concerns a connected undirected positive-weight graph with a chosen orientation; the endpoint-difference definition here also allows loops, parallel labels and arbitrary coefficients.
Mathlib's Representation.ofMulAction sends the free
basis vector at \(v\) to that at \(g\cdot v\).
Finsupp.linearEquivFunOnFinite identifies its coefficients
with functions on a finite set, yielding inverse precomposition for a
group action. Representation.IntertwiningMap bundles an
intertwiner between already supplied representations. Neither supplies
the endpoint equations or abstract sign cocycle above.
Example. What zero incidence and scalar signs forget [fdip-003C]AGENTDRAFTED
- October 29, 2026
Example. What zero incidence and scalar signs forget [fdip-003C]AGENTDRAFTED
- October 29, 2026
The signed endpoint equations retain information that an incidence operator alone can lose. Take vertices \(\{0,1\}\) and one loop \(e\) attached at \(0\). Its incidence map is zero over every ring. Swapping the vertices, fixing \(e\) and choosing sign \(+\) therefore intertwines incidence and preserves any weight on \(e\). Nevertheless \(s(q(e))=0\ne 1=p(s(e))\); the same obstruction holds for sign \(-\), since both endpoints of the loop are \(0\). This is a signed-incidence symmetry, but not a signed endpoint arrow.
A separate loss concerns composition. Let \(C_3=\{1,g,g^2\}\) fix a single loop and its vertex. Assign abstract signs \(\varepsilon _1=+\), \(\varepsilon _g=\varepsilon _{g^2}=-\). Every endpoint and zero-incidence equation holds separately. But the action cocycle at \(g\cdot g=g^2\) would require \[\varepsilon _{g^2}=\varepsilon _g\varepsilon _g=+,\] contrary to the assigned \(-\). Thus these arrows do not define a \(C_3\)-action. Over a ring of characteristic two the scalar maps all become the identity because \(-1=1\); even their representation equations then conceal the failed abstract cocycle. Orientation data remain subject to the abstract \(C_2\) law.
By contrast, one edge \(e:0\to 1\) admits the vertex swap with fixed edge label and sign \(-\). Its endpoints reverse as required, and using this arrow twice gives sign \(+\) and identity bijections. For fields, \[(dPf)(e)=f(0)-f(1)=-(df)(e)=(Jdf)(e).\] It is a valid signed symmetry. Parallel labels are still distinct: an edge bijection may permute them, but never identifies two labels. Each sign must satisfy its own endpoint rule and the composition law.
These calculations use the endpoint-difference construction of Definition [fdip-003B].
[spielman2009effective, Section 2.1, pp. 4-5] allows an arbitrary orientation of each edge. The calculations explain its extension in the signed endpoint construction.
[milne2025group, Definition 4.1, p. 57] gives the group-law requirement. Neither source is being asserted to contain these loop or characteristic-two examples.
Example. The half-turn on vertex and edge fields [fdip-000J]AGENTDRAFTED
- October 17, 2026
Example. The half-turn on vertex and edge fields [fdip-000J]AGENTDRAFTED
- October 17, 2026
The alternating four-cycle has a symmetry for every \(t>0\), including unequal weights. Let \(C_2=\{1,r\}\) with \(r^2=1\). Its left actions on the distinct vertex and edge sets \(V=\mathbb Z/4\mathbb Z\) and \(E=\{e_0,e_1,e_2,e_3\}\) are \[r\cdot i=i+2,\qquad r\cdot e_i=e_{i+2}.\] Indices are modulo \(4\). These permutations square to the identity, preserve the endpoints \(e_i:i\to i+1\), and preserve the weights \((1,t,1,t)\). Milne's [milne2025group, Definition 4.1, p. 57] gives the left-action convention; his [milne2025group, Example 7.1(b), p. 101] constructs the associated permutation representation.
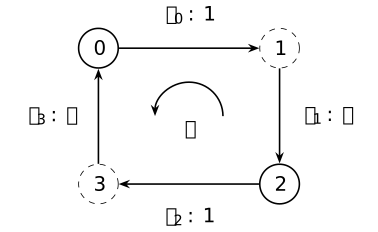
The half-turn exchanges \(0,2\) and \(1,3\), and exchanges \(e_0,e_2\) and \(e_1,e_3\). Directed arrows and their weights agree after rotation. Solid vertices form the retained set \(\{0,2\}\); the dashed vertices form its complement. Each set is preserved.
The induced maps on real fields use inverse precomposition: \[\begin {aligned} P:\mathbb R^V&\to \mathbb R^V,&(P\phi )_i&=\phi _{i-2},\\ U:\mathbb R^E&\to \mathbb R^E,&(Ua)(e_i)&=a(e_{i-2}). \end {aligned}\] Both maps have the coordinate array \[\begin {pmatrix} 0&0&1&0\\0&0&0&1\\1&0&0&0\\0&1&0&0 \end {pmatrix},\] but their domains differ. They satisfy \(P^2=I\) and \(U^2=I\). Sending \(1\) to the identity and \(r\) to these maps gives two real linear representations of \(C_2\).
Write \(\delta _i(j)=\mathbf 1_{j=i}\) for the vertex coordinate basis and \(\eta _i(e_j)=\mathbf 1_{j=i}\) for the edge coordinate basis. Then \(P\delta _0=\delta _2\ne \delta _0\) and \(U\eta _0=\eta _2\ne \eta _0\). Since \(r\) is the only nonidentity element of \(C_2\), both representations are faithful. Finite coordinate reindexing preserves the counting pairings; weight preservation gives \[\begin {aligned} P^TP&=I,\qquad U^TU=I,\\ U^TWU&=W, \end {aligned}\] where \(W=\operatorname {diag}(1,t,1,t)\). The last identity also preserves the weighted edge pairing.
The two representations interact through the incidence matrix. With its edge-by-vertex convention from [spielman2009effective, Section 2.1, p. 4], \[\begin {aligned} (BP\phi )(e_i)&=\phi _{i+1-2}-\phi _{i-2}\\ &=(UB\phi )(e_i). \end {aligned}\] Thus \(BP=UB\): the incidence map is equivariant between the vertex and edge actions.
The same formulas define linear representations over any nonzero commutative unital ring, with any period-two weights in that ring. The delta witnesses still prove faithfulness because \(1\ne 0\). Over the zero ring the two field modules have one element, so this faithfulness assertion is excluded. The positive real weights above are the specialization used for Gaussian laws.
This is the all-positive case of a signed endpoint action. The general endpoint composition, abstract orientation cocycle and weaker signed-incidence symmetry have that defining address. The loop and reversal examples explain why endpoint and sign coherence cannot be inferred from the incidence intertwiner alone.
Mathlib's Representation.ofMulAction sends a coordinate
basis vector at \(v\) to the one at \(g\cdot v\). Its finitely supported
coefficient module is identified with all functions on a finite set by
Finsupp.linearEquivFunOnFinite, giving the inverse-precomposition
convention above. Representation.IntertwiningMap bundles
a linear map with the equation \(B P_g=U_gB\). These interfaces do not
provide the particular incidence identity or the coherent signed-edge
action without their proofs.
Theorem. Pairing isometries transport incidence operators [fdip-003D]AGENTDRAFTED
- October 29, 2026
Theorem. Pairing isometries transport incidence operators [fdip-003D]AGENTDRAFTED
- October 29, 2026
Let \(k\) be a commutative unital ring. Give \(M,N,M',N'\) chosen perfect symmetric pairings, and let \(d:M\to N\), \(d':M'\to N'\) be ordinary linear maps. Suppose the linear isomorphisms \(P:M\to M'\), \(J:N\to N'\) preserve these pairings and satisfy \(d'P=Jd\). Let \(W:N\to N\), \(W':N'\to N'\) be self-adjoint maps with \(W'J=JW\). For a fixed \(\mu \in k\), put \[L=d^\dagger Wd,\qquad Q=L+\mu I_M,\] and define \(L',Q'\) by the primed data. Then \[\begin {aligned} (d')^\dagger &=Pd^\dagger J^{-1}:N'\to M',\\ L'&=PLP^{-1},\qquad Q'=PQP^{-1}. \end {aligned}\] If \(Q\) is an isomorphism, so is \(Q'\), and its inverse response satisfies \[G'=(Q')^{-1}=PQ^{-1}P^{-1}=PGP^{-1}.\] Consequently \(Qf=j\) implies \(Q'(Pf)=Pj\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
For \(z'\in M'\), pairing preservation gives \(b_{M'}(Px,z')=b_M(x,P^{-1}z')\). The uniqueness of the adjoint therefore gives \(P^\dagger =P^{-1}\), and similarly \(J^\dagger =J^{-1}\). From \(d'=JdP^{-1}\), the adjoint product law gives \((d')^\dagger =Pd^\dagger J^{-1}\). Thus \[\begin {aligned} L'&=Pd^\dagger J^{-1}W'JdP^{-1}\\ &=Pd^\dagger WdP^{-1}=PLP^{-1}. \end {aligned}\] Here \(J^{-1}W'J:N\to N\) equals \(W\); every composition is typed. The same scalar \(\mu \) gives the assertion for \(Q\). Multiplication in either order proves that \(PQ^{-1}P^{-1}\) is the inverse of \(Q'\). Finally \(Q'Pf=PQf=Pj\).
For signed endpoint arrows, the finite function modules have perfect counting duality, including empty carriers. Reindexing gives \[\begin {aligned} b_{M'}(Pf,Pg)&=\sum _{v\in V}f(v)g(v),\\ b_{N'}(Ja,Jb)&=\sum _{e\in E}\sigma (\varepsilon (e))^2a(e)b(e) =b_N(a,b). \end {aligned}\] Multiplication by transported weights obeys \(W'J=JW\), by evaluation at \(q(e)\). Thus the theorem applies without inverting any weight. It also applies to the weaker signed-incidence symmetries. The weighted edge pairing is \(b_W(a,b)=b_N(a,Wb)\); its adjoint of \(d\) into the counting vertex pairing is \(d^\dagger W\), whereas \(d^\dagger \) uses the counting edge pairing. The expression \(d^\dagger Wd\) does not require \(b_W\) to be perfect.
The inverse hypothesis cannot be replaced by a unit mass scalar. Over \(\mathbb Z\), a unit-weight edge on two vertices with \(\mu =1\) has \(Q=\begin {pmatrix}2&-1\\-1&2\end {pmatrix}\). Solving \(Q(x,y)=(1,0)\) would require \(x=2y\) and \(3y=1\), which is impossible in \(\mathbb Z\). This \(Q\) is not even surjective.
For automorphisms the conjugacies are commutation identities. They concern symmetric bilinear pairings over fixed coefficients. A grading is preserved only if \(P\) preserves its graded pieces; a star is preserved only if \(P\) commutes with that star. A nontrivial coefficient involution and Hermitian adjoint need their own conventions.
The proof uses the chosen duality construction in Proposition [fdip-001P],
with the Hom convention of
[stacks2017stacks, Section 10.10], Tag 0581.
For real graph incidence, the energy convention is
[spielman2009effective, Section 2.1, pp. 4-5]; the displayed
ring transport is a direct deduction, not a positivity theorem.
Mathlib's Matrix.reindexLinearEquiv and
Matrix.reindexRingEquiv support its coordinate reindexing
specialization, without supplying the endpoint or pairing hypotheses.
Proposition. Transport of the retained Schur map [fdip-003E]AGENTDRAFTED
- October 29, 2026
Proposition. Transport of the retained Schur map [fdip-003E]AGENTDRAFTED
- October 29, 2026
Over a commutative unital ring \(k\), give \(M=X\oplus Y\) and \(M'=X'\oplus Y'\) chosen splittings. Suppose isomorphisms \(P:M\to M'\), \(P_X:X\to X'\), \(P_Y:Y\to Y'\) preserve the inclusions and projections: \[\begin {aligned} P\iota _X&=\iota '_XP_X,&P\iota _Y&=\iota '_YP_Y,\\ \pi '_XP&=P_X\pi _X,&\pi '_YP&=P_Y\pi _Y. \end {aligned}\] Let \(Q'=PQP^{-1}\). Write its 4 split components and those of \(Q\) as \(A:X\to X\), \(B:Y\to X\), \(E:X\to Y\), \(C:Y\to Y\), and their primed versions. Then \[\begin {aligned} A'&=P_XAP_X^{-1},&B'&=P_XBP_Y^{-1},\\ E'&=P_YEP_X^{-1},&C'&=P_YCP_Y^{-1}. \end {aligned}\] If \(C\) is invertible, the split Schur maps obey \[S'=P_XSP_X^{-1},\qquad S=A-BC^{-1}E.\] For \(K=C^{-1}E:X\to Y\), \(K'=(C')^{-1}E'\), \[K'P_X=P_YK,\qquad -K'(P_Xx)=P_Y(-Kx).\] Thus the eliminated-equation field \(y_*(x)=-Kx\), the unique solution of the lower equation with zero source, is transported with its sign intact.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
For indices \(i,j\in \{X,Y\}\), the inclusion and projection identities give \[\pi '_iQ'\iota '_j =P_i(\pi _iQ\iota _j)P_j^{-1}.\] Taking \((i,j)=(X,X),(X,Y),(Y,X),(Y,Y)\) gives all 4 typed identities. Inverting the last one gives \((C')^{-1}=P_YC^{-1}P_Y^{-1}\). Substitution cancels each adjacent \(P_Y^{-1}P_Y\) in \(B'(C')^{-1}E'\), proving the Schur formula. The same substitution in \(K'\) proves \(K'P_X=P_YK\) and hence the transport identity for this field.
When \(Q\) is also invertible, the inverse-compression theorem says \[S^{-1}=\pi _XQ^{-1}\iota _X.\] Conjugating and using the split maps gives \[(S')^{-1}=P_XS^{-1}P_X^{-1} =\pi '_X(Q')^{-1}\iota '_X.\] This uses an actual inverse. No pairing has been assumed; only for an orthogonal split and self-adjoint \(Q\) does one further have \(E=B^\dagger \), by Proposition [fdip-001X]. For an orthogonal split of finite-dimensional real inner-product spaces and a positive self-adjoint \(Q\), this field is also stationary for the quadratic action in the eliminated variable, by the real square-completion argument.
For a vertex bijection \(p:V\to V'\), let \(R'=pR\), \(X=k^R\), \(X'=k^{R'}\), and let \(P_R\) be inverse precomposition by \(p|_R\). At \(p(v)\), \(v\in R\), both sides of \[\pi _{R'}P=P_R\pi _R\] take the value \(f(v)\). The target space is \(k^{pR}\), even if the labels of \(R\) and \(pR\) differ. This equation supplies the moving projection square in Gaussian marginal transport.
If a group action preserves \(R\), its restrictions compose on \(k^R\) and the square becomes \(\pi _RP_g=P_{g,R}\pi _R\). Faithfulness of the full action need not survive restriction: a permutation moving only eliminated vertices acts trivially on retained fields. The opposite-pair half-turn has a separate nontrivial retained action.
Stable subsets and equivariance follow the convention of [milne2025group, p. 58]. The real Schur convention is [boyd2004convex, Appendix A.5.5, pp. 650-651], with the source's first pivot exchanged to the eliminated \(C\) block. The typed transport proof above uses only the chosen splitting, and does not by itself supply any integral or Gaussian normalizer.
Proposition. Transport of polynomial observables and functionals [fdip-003F]AGENTDRAFTED
- October 29, 2026
Proposition. Transport of polynomial observables and functionals [fdip-003F]AGENTDRAFTED
- October 29, 2026
Let \(k\) be a commutative unital ring. For a \(k\)-module \(M\), write \(\mathcal P_k(M)\) for the unital \(k\)-subalgebra of functions \(M\to k\) generated by ordinary linear functionals. This extends the intrinsic real polynomial functions using the same pointwise operations. These are actual functions: over finite fields, distinct formal polynomials can have identical evaluations.
For a linear isomorphism \(P:M\to M'\), pullback gives a unital algebra isomorphism \[P^*:\mathcal P_k(M')\longrightarrow \mathcal P_k(M),\qquad P^*F'=F'\circ P.\] An already supplied normalized functional \(\omega \) on \(\mathcal P_k(M)\) transports to \(\omega '=\omega \circ P^*\). For the moving split square, the retained functionals \(\omega _X=\omega \circ \pi ^*\) and \(\omega '_{X'}=\omega '\circ (\pi ')^*\) satisfy \[\omega '_{X'}=\omega _X\circ P_X^*.\] Here \(\pi :M\to X\), \(\pi ':M'\to X'\) are the specified projections, and \(\pi 'P=P_X\pi \).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Precomposition preserves sums, scalar multiples, products and the constant function \(1\), by evaluation. A linear functional on \(M'\) composed with \(P\) is linear on \(M\), so pullback preserves the generated polynomial algebras. Its inverse is \((P^{-1})^*\). For composable maps, \((P'P)^*F''=F''\circ P'\circ P=P^*((P')^*F'')\); identity pullback is identity. This proves contravariance as well.
Linearity of \(\omega '\) and \(\omega '(1)=\omega (1)=1\) follow directly, or by algebra-map pullback. The section \(\iota _X\) of \(\pi \) makes \(\pi ^*\) injective: \(f\circ \pi =g\circ \pi \) implies \(f=g\) after composition with \(\iota _X\). Thus \(\omega _X\) is restriction to the image of \(\pi ^*\), identified with \(\mathcal P_k(X)\). Finally, for each \(f'\in \mathcal P_k(X')\) and \(x\in M\), \[\begin {aligned} P^*(\pi ')^*f'(x) &=f'(\pi 'Px)\\ &=f'(P_X\pi x)=(\pi ^*P_X^*f')(x). \end {aligned}\] Applying \(\omega \) gives the asserted retained-functional equality.
Over \(\mathbb R\) with the identity involution, or over \(\mathbb C\) with pointwise conjugation, suppose the chosen observable algebras are closed under that involution. Pullback then commutes with star. If \(\omega \) is an algebraic state, \[\begin {aligned} \omega '(F'^*F') &=\omega \bigl ((P^*F')^*(P^*F')\bigr )\geq 0, \end {aligned}\] and the star compatibility of the functional is preserved too. Holomorphic polynomial functions on a complex vector space are not automatically closed under conjugation; closure is an extra hypothesis. One can instead generate an algebra by both linear functionals and their conjugates; precomposition preserves those generators as well. No positivity over an arbitrary ring or existence of a measure is asserted. For the real Gaussian, absolute moments first give its polynomial state; the transported law then identifies this algebraic transport with expectation. Integrable functions as a whole are not an algebra, and restriction here is neither conditional expectation nor partial trace.
The algebra and state conventions are [stacks2017stacks, Section 22.2], Tag 09JF and [waldmann2004states, Definitions 3.7 and 3.9, p. 11]. The composition and split-square calculations are direct extensions of Proposition [fdip-002A] and Proposition [fdip-0027]; their linear-dual and star-algebra interfaces do not supply a Gaussian measure.
Definition. Finite Gaussian backgrounds and relabelings [fdip-000G]AGENTDRAFTED
- October 17, 2026
Definition. Finite Gaussian backgrounds and relabelings [fdip-000G]AGENTDRAFTED
- October 17, 2026
To compare two discrete Gaussian models, specify which data a change of labels must carry. A finite Gaussian background consists of a finite incidence presentation \((V,E,s,h)\), positive weights \(w:E\to \mathbb R_{>0}\), a mass \(m>0\), and a nonempty proper retained subset \(R\subsetneq V\). Put \(U=V\setminus R\); both retained and eliminated carriers are nonempty. The specified reference structures are the counting inner products on vertex and edge fields, the weighted edge inner product, and the induced Borel Euclidean volume \(\lambda _V\) on \(\mathbb R^V\). The orthogonal coordinate split identifies it with the product of the retained and eliminated volumes.
Let \(d:\mathbb R^V\to \mathbb R^E\) be incidence, \((df)(e)=f(h(e))-f(s(e))\), and let \(W\) multiply edge fields by \(w\). The derived operators are \[L=d^\dagger Wd,\qquad Q=L+m^2I>0,\] where \(d^\dagger \) is the counting adjoint. In counting bases, \(d\) has array \(D\) and \(L=D^TWD\). The action \(\mathcal A_Q(f)=b_V(f,Qf)/2\), finite positive normalizer \(Z_Q\), Gaussian law \(\mu _Q\), and retained marginal \(\mu _S\) are derived data. For the 4 split components, \(S=A-BC^{-1}E\); the real orthogonal specialization has \(E=B^\dagger \); the block \(B:Y\to X\) is distinct from incidence.
An exact relabeling to a primed background consists of bijections \(p:V\to V'\), \(q:E\to E'\) satisfying \[\begin {aligned} s'q&=ps,&h'q&=ph,\\ w'q&=w,&m'&=m,\qquad pR=R'. \end {aligned}\] It is the all-positive specialization of a signed endpoint arrow. It preserves the attachment of a loop even when its incidence is zero. The induced maps are \[(Pf)(p(v))=f(v),\qquad (Ja)(q(e))=a(e).\] They preserve both counting pairings, the weighted edge pairing, and by isometry of reference volume the reference volume. Allowing coherent endpoint reversals gives the larger signed relation; it does not change what an exact directed relabeling means.
Evaluation at \(q(e)\) gives \((d'Pf)(q(e))=f(h(e))-f(s(e))=(Jdf)(q(e))\). Weight preservation gives \(W'J=JW\). Thus paired transport yields \[L'=PLP^{-1},\qquad Q'=PQP^{-1}.\] Counting isometry gives \(P^{-1}=P^T\), \(J^{-1}=J^T\) in the coordinate bases, recovering \(D'=JDP^T\) and \(W'=JWJ^T\). The normalized-law theorem carries the laws and moving marginals. Identity, inverse and composition are the directed cases of the proved signed-arrow laws, so existence of an exact relabeling is an equivalence relation on backgrounds.
Two broader comparisons retain less data. The positive-scaling Laplacian relation forgets mass, state and partition, and compares nonzero Laplacians by \(L'=cPLP^{-1}\) with \(c>0\) and a vertex permutation. Its cycle trace ratio still separates two examples. An arbitrary invertible real field map \(y=T\phi \) instead changes precision to \(T^{-T}QT^{-1}\) and the counting pairing to \(y^TT^{-T}T^{-1}z\). Its reference Jacobian is \(dy=|\det T|\,d\phi \). Such a map can transport the normalized law by Jacobian compensation, while losing the reference pairing or retained projection. It is not thereby an enriched background arrow.
The covariance-parameter Gaussian density in
[friedli2017statistical, Proposition B.55, p. 505] agrees with
these conventions after the inverse-precision theorem
identifies \(\Sigma =Q^{-1}\). Its change-of-variables argument does
not specify the endpoint, mass or retained-subset data.
Mathlib's Matrix.reindexLinearEquiv and
Matrix.reindexRingEquiv support the coordinate reindexing
identities. The extra background requirements are those stated here.
Theorem. Relabeling transports the state and its marginal [fdip-000H]AGENTDRAFTED
- October 17, 2026
Theorem. Relabeling transports the state and its marginal [fdip-000H]AGENTDRAFTED
- October 17, 2026
Let \(M,M'\) be finite-dimensional real positive inner-product spaces with their induced Borel Euclidean volumes \(\lambda ,\lambda '\). Let \(Q:M\to M\) be positive and self-adjoint, and let \(P:M\to M'\) be a linear isometry equivalence. Put \(Q'=PQP^{-1}\). Then \(Q'\) is positive and self-adjoint, and the Gaussian laws satisfy \[Z_{Q'}=Z_Q,\qquad P_*\mu _Q=\mu _{Q'}.\] Borel pushforward means \((P_*\mu )(A)=\mu (P^{-1}(A))\) for every Borel set \(A\), extending the finite convention. For every real or complex Borel function \(F'\), \[\begin {aligned} \int |F'|\,d\mu _{Q'}&=\int |F'\circ P|\,d\mu _Q,\\ F'\in L^1(\mu _{Q'})&\Longleftrightarrow F'\circ P\in L^1(\mu _Q). \end {aligned}\] The first identity allows infinity. Under the equivalent finite absolute-integral conditions, \[\omega _{Q'}(F')=\omega _Q(F'\circ P).\] In particular, the target observable transported from \(F\) is \(F'=F\circ P^{-1}\). Exact and signed arrows of real backgrounds supply such isometries.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The adjoint identity gives \(P^\dagger =P^{-1}\), so \(Q'\) is self-adjoint. For \(z'=Px\ne 0\), \(b_{M'}(z',Q'z')=b_M(x,Qx)>0\); this also proves equality of Gaussian actions at \(Px\) and \(x\). The isometry-volume theorem gives \(P_*\lambda =\lambda '\). Consequently, for every nonnegative Borel \(h'\), \[\begin {aligned} &\int h'(z')e^{-\mathcal A_{Q'}(z')}\,d\lambda '(z')\\ &\qquad =\int h'(Px)e^{-\mathcal A_Q(x)}\,d\lambda (x). \end {aligned}\] Take \(h'=1\); the positive Gaussian integral gives finite nonzero normalizers, and this equality proves \(Z_{Q'}=Z_Q\). Then take \(h'=\mathbf 1_A/Z_Q\) to obtain \(\mu _{Q'}(A)=\mu _Q(P^{-1}(A))\) for every Borel \(A\).
Taking \(h'=|F'|/Z_Q\) gives the extended absolute-integral identity and hence the integrability equivalence. If finite, positive and negative parts give the expectation identity; real and imaginary parts give the complex version. Every real polynomial function is integrable by absolute Gaussian moments. On that algebra the expectation identity agrees with the previously proved functional transport. No algebra structure on all of \(L^1\) is required.
For linear functionals \(\ell ',r'\in (M')^\vee \), finite second moments and the pushforward give the intrinsic covariance identity \[\operatorname {Cov}_{Q'}(\ell ',r') =\operatorname {Cov}_{Q}(\ell '\circ P,r'\circ P).\] The inverse-precision covariance theorem says that, relative to the specified pairings, \(\operatorname {Cov}_Q(b_M(u,-),b_M(v,-))=b_M(u,Q^{-1}v)\). Since \(b_{M'}(u',Px)=b_M(P^{-1}u',x)\), this yields \[G'=PGP^{-1},\qquad G=Q^{-1}.\] In orthonormal coordinates this is \(G'=PGP^T\); an arbitrary linear coordinate map gives covariance congruence instead, as in Proposition [fdip-003M]. Equality of second moments was not used to infer the pushforward law.
Now let \(M=X\oplus Y\) and \(M'=X'\oplus Y'\) be orthogonal splittings that \(P\) carries by isometries \(P_X,P_Y\), so the split-square hypotheses hold. For the 4 components, \[\begin {aligned} A'&=P_XAP_X^{-1},&B'&=P_XBP_Y^{-1},\\ E'&=P_YEP_X^{-1},&C'&=P_YCP_Y^{-1}. \end {aligned}\] Here \(E=B^\dagger \), and \(C>0\). The retained precisions and eliminated Gaussian factors satisfy \[\begin {aligned} S'&=P_XSP_X^{-1},& S&=A-BC^{-1}E>0,\\ c_{C'}&=c_C,&c_C&=\frac {(2\pi )^{\dim Y/2}}{\sqrt {\det C}},\\ Z_{S'}&=Z_S,&(P_X)_*\mu _S&=\mu _{S'}. \end {aligned}\] Thus the complete fiber scalar and the additive effective-action constant \(-\log c_C\) are preserved, along with the normalized law.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The 4 blocks and Schur conjugacy are Proposition [fdip-003E]. A basis of \(Y\) and its image under \(P_Y\) give the same array for \(C\) and \(C'\), hence equal determinants; the dimensions are also equal. This proves \(c_{C'}=c_C\). The first part of the theorem applied on \(X\) proves \(Z_{S'}=Z_S\). The exact integration formula, for the induced product volumes, is \[\int _Y e^{-\mathcal A_Q(x,y)}\,d\lambda _Y(y) =c_Ce^{-b_X(x,Sx)/2}.\] The event marginal theorem proves \(\pi _*\mu _Q=\mu _S\) and \(\pi '_*\mu _{Q'}=\mu _{S'}\). Pushforwards compose by inverse images of Borel sets. Using \(\pi 'P=P_X\pi \), one obtains \[\begin {aligned} (P_X)_*\mu _S &=(P_X\pi )_*\mu _Q\\ &=(\pi 'P)_*\mu _Q=\pi '_*\mu _{Q'}=\mu _{S'}. \end {aligned}\] This proves moving marginal transport from actual measures, rather than from Schur or covariance identities alone. The same marginal supplier gives the extended absolute-integral identity for retained observables and the polynomial-state restriction.
For vertex bijections \(p:V\to V'\), take a nonempty proper \(R\subsetneq V\), set \(R'=pR\), and use the coordinate splits. The map \(P_R:\mathbb R^R\to \mathbb R^{R'}\) has the genuine moving target \(\mathbb R^{pR}\). At \(p(v)\), \(v\in R\), both \(\pi _{R'}Pf\) and \(P_R\pi _Rf\) have value \(f(v)\). Thus:
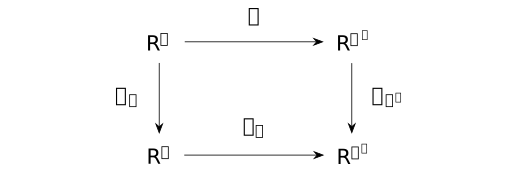
The lower map exists because the retained subset is transported. Keeping the target labels fixed can select an inequivalent marginal; the adjacent-versus-opposite example gives both the precision calculation and a failure of projection factorization.
These conclusions use positive precisions and the stated product volumes. Fixing an eliminated field, taking a conditional-density kernel, and taking a marginal are different operations. A singular full-fiber integral is not repaired by a pseudoinverse: changing the integration space changes the measure. The massless projected cycle law has its proved density on the specified retained image, and is not obtained by inserting a mean-zero constraint into the unconstrained marginal formula.
[friedli2017statistical, Proposition B.55, p. 505] gives the Gaussian change-of-variables convention.
[tao2011measure, Theorem 1.7.15, pp. 200-202] gives the nonnegative integration convention on the Borel product measures; absolute integrability precedes signed subtraction.
[boyd2004convex, Appendix A.5.5, pp. 650-651] gives the real block convention, with its first pivot exchanged to \(C\).
Mathlib's LinearIsometryEquiv.measurePreserving
supplies volume preservation for finite-dimensional real linear
isometry equivalences. TauCeti's
TauCeti.Probability.map_affine_multivariateGaussian
supplies covariance-parameter transport. Set mean and shift to zero,
linear map to \(P\), and covariance to \(Q^{-1}\); the
precision-density identification and the proved inverse
identity align it with this law. These interfaces do not supply the
endpoint data, declared partition or its counterexample.
Theorem. Symmetry survives the Gaussian marginal [fdip-000K]AGENTDRAFTED
- October 17, 2026
Theorem. Symmetry survives the Gaussian marginal [fdip-000K]AGENTDRAFTED
- October 17, 2026
Let a group \(\Gamma \) act by a signed-incidence symmetry on a finite incidence presentation with positive real weights and nonempty vertex set. Use the counting pairings, their induced Borel volume and a scalar mass \(m>0\). The positive massive precision and inverse-precision covariance are \[L=d^\dagger Wd,\qquad Q=L+m^2I,\qquad G=Q^{-1}.\] For every \(g\in \Gamma \), \[\begin {aligned} LP_g&=P_gL,&QP_g&=P_gQ,\\ GP_g&=P_gG,&P_gGP_g^\dagger &=G. \end {aligned}\] Thus \(Qf=j\) implies \(Q(P_gf)=P_gj\). The Gaussian law is invariant: \((P_g)_*\mu _Q=\mu _Q\). For every real or complex Borel observable \(F\), \[\begin {aligned} \int |F\circ P_g|\,d\mu _Q&=\int |F|\,d\mu _Q,\\ \omega _Q(F\circ P_g)&=\omega _Q(F) \end {aligned}\] with extended integrals in the first equality, and finite absolute integral required in the second.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The signed action gives counting isometries and \(dP_g=J_gd\), \(WJ_g=J_gW\). The paired transport theorem gives the stated commutations; \(P_g^\dagger =P_g^{-1}\) gives the covariance congruence. The unique sourced solution is \(f=Gj\). At zero source this is zero, although the action on the entire field carrier need not be trivial.
The scalar Euclidean action \(\mathcal A_Q(f)=b(f,Qf)/2\) satisfies \(\mathcal A_Q(P_gf)=\mathcal A_Q(f)\) by pairing isometry and commutation. This scalar function differs from the group action \(g\mapsto P_g\). The Gaussian transport theorem, with \(Q'=Q\), proves event-law invariance and the extended absolute integral before the expectation assertion. Its proof applies to the weaker incidence intertwiners and therefore to signed endpoint actions; no directed-endpoint claim is inferred from the weaker hypotheses.
Suppose further that a nonempty proper retained subset \(R\subsetneq V\) is stable under every \(p_g\). Its complement \(D=V\setminus R\) is also stable. The restricted maps \(P_{g,R},P_{g,D}\) give the orthogonal split correspondence. For the split components \(A,B,E,C\), with \(E=B^\dagger \), and \(S=A-BC^{-1}E>0\), one has \[\begin {aligned} P_{g,R}SP_{g,R}^{-1}&=S,\\ P_{g,R}S^{-1}P_{g,R}^{-1}&=S^{-1},\\ (P_{g,R})_*\mu _S&=\mu _S. \end {aligned}\] The retained equation \(Sx=k\) is equivariant as well. The full fiber factor \(c_C=(2\pi )^{|D|/2}/\sqrt {\det C}\) and the stationary eliminated field are compatible with the action: \[y_*(P_{g,R}x)=P_{g,D}y_*(x),\qquad y_*(x)=-C^{-1}Ex.\]
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The four-block transport identities give Schur conjugacy, its inverse conjugacy, and stationary-field transport. Its actual projection identity is \(\pi _RP_g=P_{g,R}\pi _R\). By the normalized marginal theorem and full-law invariance, \[\begin {aligned} (P_{g,R})_*\mu _S &=(P_{g,R}\pi _R)_*\mu _Q\\ &=(\pi _RP_g)_*\mu _Q=\pi _{R*}\mu _Q=\mu _S. \end {aligned}\] The real transport theorem also proves invariance of \(\det C\), \(c_C\), the additive action constant and \(Z_S\). For every integrable retained observable \(f\), \[\begin {aligned} \omega _S(f\circ P_{g,R})&=\omega _S(f),\\ \omega _Q(f\circ \pi _R)&=\omega _S(f). \end {aligned}\] The marginal theorem supplies the absolute-integral equivalence needed here. On actual polynomial functions this is the retained functional square. Gaussian integration proves the law; algebraic Schur conjugacy by itself does not.
For the half-turn, retain \(R=(0,2)\) and eliminate \(D=(1,3)\). Both restrictions are the nonidentity swap \(J=\begin {pmatrix}0&1\\1&0\end {pmatrix}\). Here \(H\) is the array of the split component \(B\). The projection square is
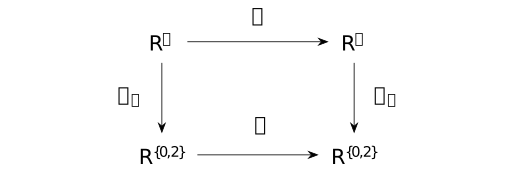
The lower map swaps the two retained coordinates. Put \(a=m^2\) and \(s=1+t+a\). The explicit elimination gives \[\begin {aligned} A=C&=sI_2,\qquad H=-\begin {pmatrix}1&t\\t&1\end {pmatrix},\\ S&=\begin {pmatrix}\alpha &-\beta \\-\beta &\alpha \end {pmatrix},\\ \alpha &=s-\frac {1+t^2}{s},\qquad \beta =\frac {2t}{s}. \end {aligned}\] All three blocks commute with \(J\), hence \(JSJ=S\). Positivity follows also from the two eigenvalues \[\begin {aligned} \alpha -\beta &=\frac {a(a+2+2t)}s>0,\\ \alpha +\beta &=\frac {(a+2)(a+2t)}s>0. \end {aligned}\] Thus the same nontrivial action preserves the full and retained laws. The full covariance obeys \(G_{i+2,j+2}=G_{ij}\). Invariant state does not mean that each observable is pointwise invariant: \(\phi \mapsto \phi _0^2\) is sent to \(\phi \mapsto \phi _2^2\); they differ at \(\delta _0\), but their expectations agree.
At \(t=m=1\), direct inversion gives \[\begin {aligned} S&=\begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix},\\ S^{-1}&=\begin {pmatrix}7/15&2/15\\2/15&7/15\end {pmatrix}. \end {aligned}\] Both swapped squared coordinates have expectation \(7/15\). The observable \(\phi _0\phi _2\) is itself invariant under the half-turn and has expectation \(2/15\). These expectations agree before and after elimination.
The full and retained half-turns are both faithful: their nonidentity maps send \(\delta _0\) to \(\delta _2\). A general full faithful action can restrict trivially, for instance when it moves only eliminated vertices. These two assertions are compatible.
Three concrete obstructions distinguish the hypotheses: keeping fixed target labels after relabeling, breaking the alternating weights, and choosing a nonstable retained subset. The last is a failure of descent through that projection and does not exclude accidental symmetry of a marginal density. Extra mass fields or reference pairings would require their own preservation hypotheses.
[milne2025group, Definition 4.1 and p. 58] gives the group-action and stable-subset conventions.
[friedli2017statistical, Proposition B.55, p. 505] gives the Gaussian substitution convention. The incidence, stationary and half-turn computations above use the proved transport results and the exact cycle elimination.
Mathlib's LinearIsometryEquiv.measurePreserving
supplies isometry-volume preservation. TauCeti's
TauCeti.Probability.map_affine_multivariateGaussian
supports covariance-parameter pushforward for the supplied \(P_g\)
or retained projection after the precision-density bridge.
These declarations do not assert the endpoint, weight or stable-subset
hypotheses, or the concrete failures just cited.
Example. Fixed labels can select a different marginal [fdip-003J]AGENTDRAFTED
- October 29, 2026
Example. Fixed labels can select a different marginal [fdip-003J]AGENTDRAFTED
- October 29, 2026
A global relabeling need not preserve a marginal requested on fixed labels. In the four-cycle, take \(t=m=1\) and retain \(R=\{0,2\}\). Its effective precision is \[S_{\mathrm {opp}}= \begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix}.\] Exchange labels \(1,2\), fixing \(0,3\), and form \(Q'=PQP^T\). If the new retained labels are still \(\{0,2\}\), they select the original adjacent variables \(\{0,1\}\). In the old coordinate order \((0,1)\mid (2,3)\), the relevant blocks are \[\begin {aligned} A=C&=\begin {pmatrix}3&-1\\-1&3\end {pmatrix},\\ H&=\begin {pmatrix}0&-1\\-1&0\end {pmatrix},\\ C^{-1}=HC^{-1}H^T &=\frac 18\begin {pmatrix}3&1\\1&3\end {pmatrix}. \end {aligned}\] Subtraction gives \[S_{\mathrm {adj}}= \begin {pmatrix}21/8&-9/8\\-9/8&21/8\end {pmatrix}.\] The diagonal entries \(7/3\) and \(21/8\) differ, so no two-coordinate permutation conjugates these precisions. There is also no map on the old retained fields factoring \(\pi _RP\) through \(\pi _R\): the fields \(0\) and \(\delta _1\) have the same old projection, but their projections after \(P\) are \(0\) and \((0,1)\). Here \(\delta _1\) is the delta field at vertex \(1\), not the edge label \(e_1\). Transporting the retained subset to \(p(R)=\{0,1\}\) in the new labels restores the square and the marginal transport theorem.
The blocks are a direct calculation from the alternating-cycle precision, using the Schur convention of [boyd2004convex, Appendix A.5.5, pp. 650-651] after exchanging its first pivot to \(C\). The example separates a fixed set of labels from the moving retained space required by Proposition [fdip-003E].
Example. Breaking the weights breaks the half-turn [fdip-003K]AGENTDRAFTED
- October 29, 2026
Example. Breaking the weights breaks the half-turn [fdip-003K]AGENTDRAFTED
- October 29, 2026
In the alternating four-cycle, take \(t,m>0\) and the half-turn. It fails to preserve the action after a specific positive change of weights. Replace \((1,t,1,t)\) by \((1,t,2,t)\) while keeping the proposed half-turn. Then \(L_{00}=1+t\) and \(L_{22}=2+t\), so \(PLP^T\ne L\) and \(\mathcal A(\delta _2)-\mathcal A(\delta _0)=1/2\). If its Gaussian law were invariant, second moments would give \(PGP^T=G\); inversion would give \(PQP^T=Q\), contradicting those diagonal entries. At \(t=m=1\), retain the opposite pair \(R=(0,2)\) and eliminate \(D=(1,3)\). The blocks in that order are \[\begin {aligned} A=C&=\operatorname {diag}(3,4),\\ H&=-\begin {pmatrix}1&1\\1&2\end {pmatrix},\\ S_{\mathrm {broken}} &=\begin {pmatrix}29/12&-5/6\\-5/6&8/3\end {pmatrix}. \end {aligned}\] Indeed \[HC^{-1}H^T=\begin {pmatrix}7/12&5/6\\5/6&4/3\end {pmatrix},\] and subtracting from \(A\) gives the displayed precision. Its diagonal entries differ by \(1/4\), so its marginal also fails swap invariance. Its positive Gaussian still exists.
[spielman2009effective, Section 2.1, pp. 4-5] gives the edge-once convention.
[boyd2004convex, Appendix A.5.5, pp. 650-651] gives the positive Gaussian elimination convention. The action difference and matrix products are direct calculations with these conventions. Weight preservation is sufficient in the general transport theorem; it need not be necessary for every presentation with redundant loops or parallel edges. This example establishes failure for the stated weights, not a universal necessity.
Example. A nonstable retained set need not inherit the action [fdip-003L]AGENTDRAFTED
- October 29, 2026
Example. A nonstable retained set need not inherit the action [fdip-003L]AGENTDRAFTED
- October 29, 2026
In the alternating four-cycle with weights \((1,t,1,t)\) and \(t,m>0\), consider the half-turn and the adjacent retained subset \(R=\{0,1\}\). The half-turn preserves the full state, but sends \(R\) to \(D=\{2,3\}\). No map \(T\) of retained fields can satisfy \(\pi _RP=T\pi _R\): the zero field forces \(T(0)=0\), while \(\delta _2\) has retained projection zero and projects to \((1,0)\) after the half-turn. The action transports the marginal to a different subset; it does not descend through this fixed projection. This does not exclude accidental symmetries of an individual two-site density. A general restricted action may also be trivial, unlike the opposite-pair swap. Extra mass fields or reference pairings would require their own preservation hypotheses.
The stable-subset requirement is the equivariance convention of [milne2025group, p. 58]. The two-field witness proves failure of factorization even through a nonlinear function. It differs from the fixed-label relabeling failure: here the full half-turn symmetry is unchanged, and the chosen projection fails to admit its action. The moving square of Proposition [fdip-003E] remains valid on \(\mathbb R^{pR}\). Over any nonzero commutative unital coefficient ring \(k\), the same delta-field witness works on \(k^V\); over the zero ring all fields coincide.
Definition. Intrinsic trace on a finite free module [fdip-003G]AGENTDRAFTED
- October 29, 2026
Definition. Intrinsic trace on a finite free module [fdip-003G]AGENTDRAFTED
- October 29, 2026
A trace can be defined before choosing a pairing or displaying a matrix. Let \(k\) be a commutative unital ring and \(M\) a finite free \(k\)-module. A finite dual frame is a finite family \(m_i\in M\), \(\ell _i\in M^\vee \) such that \[x=\sum _i\ell _i(x)m_i\qquad (x\in M).\] A basis and its coefficient functionals supply such a frame; the counting carrier \(k^V\) uses its delta dual frame. For an endomorphism \(T:M\to M\), define its intrinsic trace by \[\operatorname {tr}_M(T)=\sum _i\ell _i(Tm_i).\] This scalar is independent of the frame. It is linear in \(T\), and for maps between finite free modules \(f:M\to N\), \(g:N\to M\), \[\operatorname {tr}_M(gf)=\operatorname {tr}_N(fg).\] In particular, for an isomorphism \(P:M\to M'\), \[\operatorname {tr}_{M'}(PTP^{-1})=\operatorname {tr}_M(T).\]
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Let \(n_j,\psi _j\) be another dual frame of \(M\). Expanding \(m_i\) in this frame and commuting the scalars in \(k\) gives \[\begin {aligned} \sum _i\ell _i(Tm_i) &=\sum _{i,j}\psi _j(m_i)\ell _i(Tn_j)\\ &=\sum _j\psi _j(Tn_j). \end {aligned}\] For the last equality, evaluate \(\sum _i\psi _j(m_i)\ell _i(x)=\psi _j(\sum _i\ell _i(x)m_i)=\psi _j(x)\) at \(x=Tn_j\). This proves frame independence without a pairing. Termwise addition and scalar multiplication give \(\operatorname {tr}(T+U)=\operatorname {tr}(T)+\operatorname {tr}(U)\) and \(\operatorname {tr}(cT)=c\operatorname {tr}(T)\).
Take dual frames \(m_i,\ell _i\) for \(M\) and \(n_j,\psi _j\) for \(N\). Expanding \(fm_i\) and \(gn_j\) gives \[\begin {aligned} \operatorname {tr}_M(gf) &=\sum _{i,j}\psi _j(fm_i)\ell _i(gn_j)\\ &=\operatorname {tr}_N(fg). \end {aligned}\] This is rectangular cyclicity; the two traces may be on different modules. The transported family \(Pm_i,\ell _iP^{-1}\) is a dual frame of \(M'\). Substitution into the defining sum proves the conjugacy formula.
With a basis, \(\ell _i(Tm_i)\) is the \(i\)-th diagonal coefficient, so coordinate trace is recovered as \(\sum _iT_{ii}\). For the zero module the empty frame gives trace zero; the same formulas also make sense over the zero ring. The declared category here is finite free modules. No totalized trace on arbitrary modules and no finite-projective extension are needed.
The duality/evaluation convention is [stacks2017stacks, More on Algebra, Lemma 74.1], Tag 0FNJ. [stacks2017stacks, Exercises, Exercise 22.6], Tag 02DU asks for trace, naturality and cyclicity on finite locally free modules; the finite-free proof above is supplied here, rather than attributed to a proof in that exercise.
Mathlib's LinearMap.trace has a totalized definition.
On the finite-free commutative-ring domain, its
LinearMap.trace_comp_comm' is rectangular cyclicity and
LinearMap.trace_conj' is conjugacy by a linear equivalence.
The definition above uses only this finite-free domain.
Matrix.trace_mul_comm expresses the coordinate rectangular
identity; a trace pairing is not an assumption of either construction.
Proposition. The trace ratio on its unit-denominator domain [fdip-003H]AGENTDRAFTED
- October 29, 2026
Proposition. The trace ratio on its unit-denominator domain [fdip-003H]AGENTDRAFTED
- October 29, 2026
Let \(L:M\to M\) be an endomorphism of a finite free module over a commutative unital ring \(k\). On the domain \(\operatorname {tr}_M(L)\in k^\times \), define the trace ratio \[R(L)=\operatorname {tr}_M(L^2)\bigl (\operatorname {tr}_M(L)\bigr )^{-2},\] using intrinsic trace. If \(P:M\to M'\) is an isomorphism, \(c\in k^\times \), and \(L'=cPLP^{-1}\), then \(\operatorname {tr}_{M'}(L')\) is a unit and \(R(L')=R(L)\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Put \(a=\operatorname {tr}_M(L)\). Linearity, conjugacy and \((L')^2=c^2PL^2P^{-1}\) give \[\begin {aligned} \operatorname {tr}_{M'}(L')&=ca,\\ \operatorname {tr}_{M'}((L')^2)&=c^2\operatorname {tr}_M(L^2). \end {aligned}\] Both \(c\) and \(a\) are units, so \(ca\) is a unit with inverse \(a^{-1}c^{-1}\). Substitution cancels \(c^2\) from the ratio.
Consider a finite-dimensional positive inner-product space over \(\mathbb R\). A nonzero self-adjoint positive-semidefinite operator on it has positive trace. Indeed an orthonormal eigenbasis gives eigenvalues \(\lambda _i\geq 0\); if all were zero the operator would be zero. Hence \(\operatorname {tr}L=\sum _i\lambda _i>0\). This verifies the denominator for a nonzero positive-weight graph Laplacian.
[boyd2004convex, Appendix A.5.2, pp. 646-647] gives the spectral and trace formulas. The exceptional examples show why nonzero alone is insufficient over other rings or without positivity.
For nonzero real positive-semidefinite Laplacians with their counting pairings, write \(L\approx L'\) when \(L'=cPLP^{-1}\) for a positive scalar and a vertex permutation. Identity uses \((1,I)\); inverse uses \((c^{-1},P^{-1})\); composition uses the products of the scalars and permutations. This is an equivalence relation with invariant \(R\). It forgets the mass, normalized state and retained partition of an enriched background. It also differs from arbitrary congruence of bilinear-form arrays: the ratio compares the associated endomorphisms. It is an invariant, not a classification assertion.
The ring calculation is a direct consequence of Definition [fdip-003G],
whose trace convention is
[stacks2017stacks, Exercise 22.6], Tag 02DU.
Mathlib's Matrix.trace_smul supplies the coordinate scalar
identity; the unit domain and cancellation above are additional
hypotheses and deductions. The cycle comparison computes
the invariant and the associated normalized observables explicitly.
Example. Nonzero operators outside the trace-ratio domain [fdip-003I]AGENTDRAFTED
- October 29, 2026
Example. Nonzero operators outside the trace-ratio domain [fdip-003I]AGENTDRAFTED
- October 29, 2026
The unit condition in the trace ratio distinguishes several elementary cases. For one unit-weight edge on two vertices, the Laplacian over \(\mathbb Z\) is \[L=\begin {pmatrix}1&-1\\-1&1\end {pmatrix}.\] Its trace is \(2\), which is not a unit in \(\mathbb Z\); the defining formula therefore does not give a \(\mathbb Z\)-valued ratio. After inverting \(2\) it does: \(L^2=2L\) gives ratio \(1\). Reduction over \(\mathbb F_2\) instead gives the nonzero matrix \[\overline L=\begin {pmatrix}1&1\\1&1\end {pmatrix},\] whose trace is zero and whose square is zero. Nonzero incidence energy as an algebraic operator does not imply a unit trace.
Over \(\mathbb R\), the nonzero self-adjoint matrix \(\operatorname {diag}(1,-1)\) has trace zero. It is not positive semidefinite, so it does not contradict the positive-trace proof. For an incidence presentation containing only loops, \(d=0\) and \(L=d^\dagger Wd=0\); the trace is zero whatever the loop weights. The empty carrier likewise has zero trace by the empty dual-frame sum. In each case the ratio is undefined over a nonzero ring.
In the zero ring, \(0=1\) is its sole unit, and every unital module and scalar has one element. The formula for the ratio then has the unique value \(0\). This algebraic convention makes no assertion about a nonzero positive-real Laplacian.
[spielman2009effective, Section 2.1, pp. 4-5] gives the edge-once incidence convention used here, as extended algebraically in Definition [fdip-003B]. These computations also use the directly proved dual-frame trace.
[boyd2004convex, Appendix A.5.2, pp. 646-647] gives the spectral criterion for the real positivity boundary. The ring reductions and zero-ring conclusion are the explicit calculations here, not probability statements from those sources.
Example. A trace ratio separates two weighted cycles [fdip-000I]AGENTDRAFTED
- October 17, 2026
Example. A trace ratio separates two weighted cycles [fdip-000I]AGENTDRAFTED
- October 17, 2026
The alternating cycles at \(t=1\) and \(t=2\) remain different even under the positive-scaling Laplacian comparison \(L'=cPLP^{-1}\), with \(c>0\) and \(P\) a vertex permutation. Use the trace ratio \[R(L)=\frac {\operatorname {tr}(L^2)}{(\operatorname {tr}L)^2},\] where the trace is the intrinsic endomorphism trace. The positive graph energy gives a nonzero positive-semidefinite \(L_t\) for \(t>0\), so its trace is positive and the ratio is defined. The cited proposition proves invariance by trace conjugacy and scalar cancellation. It compares counting-relative operators, not bilinear-form arrays under arbitrary congruence.
[boyd2004convex, Appendix A.5.2, pp. 646-647] gives the symmetric spectral and trace formulas. The spectral cycle calculation supplies the concrete basis; the following traces and comparisons are direct computations.
For the alternating four-cycle, \(t>0\), the orthonormal spectral basis gives eigenvalues \(0,2,2t,2+2t\), including at \(t=1\). Consequently \[\begin {aligned} \operatorname {tr}L_t&=4(1+t),\\ \operatorname {tr}(L_t^2) &=4+4t^2+4(1+t)^2\\ &=8(t^2+t+1),\\ R(t):=R(L_t)&=\frac {t^2+t+1}{2(t+1)^2}. \end {aligned}\] In particular \[\begin {aligned} R(1)&=\frac 38,\qquad R(2)=\frac 7{18},\\ R(2)-R(1)&=\frac 1{72}>0. \end {aligned}\] There can be no \(c>0\) and vertex permutation \(P\) with \(L_2=cPL_1P^T\). Thus the associated finite Gaussian backgrounds cannot be exactly relabeled into each other either. This calculation separates the stated pair; it does not claim a classification of all backgrounds.
The reciprocal identity \(R(t)=R(1/t)\) is consistent with this comparison. A one-step rotation \(p(i)=i+1\pmod 4\) exchanges the alternating edge weights \(1,t\) and leaves the common diagonal \(1+t\) unchanged. Its coordinate permutation therefore satisfies \[PL_tP^T=tL_{1/t}.\] Since \(1/t>0\), the reciprocal Laplacians are equivalent under \(\approx \). Their equal ratios do not demonstrate a failure of completeness. On the strict enriched slice with weights \((1,t,1,t)\), fixed mass and fixed opposite retained pair, the weight product is \(t^2\), whereas at parameter \(1/t\) it is \(t^{-2}\). A weight-preserving edge bijection would preserve this product; for positive \(t\) equality forces \(t=1\). Thus the broader reciprocal comparison is not a strict background isomorphism for \(t\ne 1\).
A fixed-mass calculation shows what changes in the induced state. Set \(m=1\) and retain the same labeled vertices \(R=\{0,2\}\). The alternate-vertex elimination has \(s=t+2\), giving \[\begin {aligned} \alpha (t)&=s-\frac {1+t^2}{s}=\frac {4t+3}{t+2},\\ \beta (t)&=\frac {2t}{t+2},\\ S_t&=\begin {pmatrix}\alpha (t)&-\beta (t)\\ -\beta (t)&\alpha (t)\end {pmatrix}. \end {aligned}\] Hence the effective coupling changes from \(\beta (1)=2/3\) to \(\beta (2)=1\), and the two precisions are \[\begin {aligned} S_1&=\begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix},\\ S_2&=\begin {pmatrix}11/4&-1\\-1&11/4\end {pmatrix}. \end {aligned}\] Their determinants are \(5\) and \(105/16\). The off-diagonal entry of \(S_t^{-1}\) is \(\beta (t)/\det S_t\). By the marginal expectation identity, the same labeled observable therefore has different normalized expectations: \[\begin {aligned} \langle \phi _0\phi _2\rangle _{t=1,m=1}&=\frac {2}{15},\\ \langle \phi _0\phi _2\rangle _{t=2,m=1}&=\frac {16}{105}. \end {aligned}\] This comparison fixes the mass, coordinates, reference pairing and partition. The labeled observable is not itself asserted invariant under every relabeling; the trace ratio already established the broader inequivalence.
Scale invariance of \(R\) does not mean equality of fixed-mass states. On an eigenvector of \(L\) with eigenvalue \(\lambda >0\), replacing \(L\) by \(cL\) changes the covariance eigenvalue from \(1/(\lambda +m^2)\) to \(1/(c\lambda +m^2)\) when \(c\ne 1\). Scaling all of \(Q\) instead gives covariance \(c^{-1}G\) and Schur map \(cS\), by inversion and the Schur formula. Changing mass can also leave \(R(L)\) unchanged while changing the law. The exact finite differences above do not construct a physical map from an environment to the parameter \(t\).
The trace identities and their formalization correspondence are at Definition [fdip-003G] and Proposition [fdip-003H]. Their unit-domain hypotheses specialize here to positive real trace; the values and normalized expectation comparisons above are additional cycle calculations.
Proposition. Jacobian compensation in normalized Gaussian transport [fdip-003M]AGENTDRAFTED
- October 29, 2026
Proposition. Jacobian compensation in normalized Gaussian transport [fdip-003M]AGENTDRAFTED
- October 29, 2026
Let \(M,M'\) be finite-dimensional real positive inner-product spaces with induced Borel Euclidean volumes \(\lambda ,\lambda '\). Let \(Q,Q'\) be positive self-adjoint precisions, and suppose a linear isomorphism \(T:M\to M'\) preserves their actions: \[\mathcal A_{Q'}(Tx)=\mathcal A_Q(x).\] It need not preserve the reference pairings. For its absolute Jacobian \(J(T)>0\), one has \[\begin {aligned} T_*\lambda &=J(T)^{-1}\lambda ',\\ Z_{Q'}&=J(T)Z_Q,\qquad T_*\mu _Q=\mu _{Q'}. \end {aligned}\] For every real or complex Borel observable \(F'\), \[\int |F'|\,d\mu _{Q'}=\int |F'\circ T|\,d\mu _Q\] as extended nonnegative integrals. Hence integrability is equivalent on the two sides, and, under that condition, \(\omega _{Q'}(F')=\omega _Q(F'\circ T)\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
The reference-volume change formula gives the pushforward of volume, equivalently \(\int h'\,d\lambda '=J(T)\int h'\circ T\,d\lambda \) for every nonnegative Borel \(h'\). Apply it to the Gaussian weight; action preservation gives \(Z_{Q'}=J(T)Z_Q\). Both normalizers are finite and positive by Theorem [fdip-002T]. For a nonnegative Borel \(h'\), divide the same substitution by this equality: \[\begin {aligned} \int h'\,d\mu _{Q'} &=\frac {J(T)}{Z_{Q'}}\int h'(Tx)e^{-\mathcal A_Q(x)}\,d\lambda (x)\\ &=\int h'\circ T\,d\mu _Q. \end {aligned}\] Indicators of Borel sets prove the event-pushforward statement. Taking \(h'=|F'|\) proves the extended absolute-integral equality. Only when finite do positive/negative parts, and for complex functions real/imaginary parts, give the stated expectation identity.
In orthonormal coordinates, action preservation means \(T^TQ'T=Q\), so inversion gives \[(Q')^{-1}=TQ^{-1}T^T.\] This is covariance congruence, not generally operator similarity. The scalar Jacobian is computed in the specified reference volumes; independently ordered orthonormal frames may change the signed determinant but not its absolute value. The quadratic-isometry example shows that this normalized transport can lose both counting-pairing and retained-projection compatibility. Such maps are not enriched background arrows.
The volume convention is
[tao2011measure, Exercises 1.2.20-22, p. 41]; the covariance-parameter
Gaussian substitution is
[friedli2017statistical, Proposition B.55, p. 505].
The inverse-precision covariance theorem identifies its
covariance with \(Q^{-1}\) for these reference pairings.
TauCeti's
TauCeti.Probability.map_affine_multivariateGaussian
supports the covariance congruence for a supplied finite real linear
map, even rectangular. That broader covariance result does not assert
invertibility, endpoint preservation or the retained square used here.
Group-algebra sectors [fdip-001A]AGENTDRAFTED
- October 20, 2026
Group-algebra sectors [fdip-001A]AGENTDRAFTED
- October 20, 2026
How can the same half-turn act on different Gaussian states? The group-algebra extension and its module projectors separate the actual half-turn sectors whenever two is invertible. The action and its projectors are specified before a probability law is attached. Support parity and sign sectors are different decompositions of the same fields.
Over the reals, an orthogonal involution commuting with positive precision gives a product law; the four-cycle calculation computes its two blocks and retained marginals. Symmetry still permits mixing within a sector, and in characteristic two the action survives without the complementary projectors. These examples separate the supplied symmetry, the coefficient assumptions and the choice of state.
Theorem. Extending a group action on a ring module [fdip-003N]AGENTDRAFTED
- October 29, 2026
Theorem. Extending a group action on a ring module [fdip-003N]AGENTDRAFTED
- October 29, 2026
Let \(k\) be a commutative unital ring, \(G\) a group and \(M\) a unital \(k\)-module. A linear action \(\rho :G\to \operatorname {Aut}_k(M)\) extends uniquely to a unital \(k\)-algebra homomorphism \[\widehat \rho :k[G]\longrightarrow \operatorname {End}_k(M),\qquad \widehat \rho \left (\sum _g a_g[g]\right )=\sum _g a_g\rho (g).\] Products of endomorphisms compose right to left. This extends the Group Algebra universal property to the actual module action; no finiteness of \(G\) is assumed.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Elements of \(k[G]\) are finite-support functions on \(G\). The coefficient of \([u]\) in a product is \(\sum _{gh=u}a_gb_h\); only pairs in the finite set \(\operatorname {supp}(a)\times \operatorname {supp}(b)\) contribute. Its image under multiplication contains the product support. Associativity follows by reassociating the finite triple sum and using \((gh)j=g(hj)\). The unit is \([1_G]\), and the scalar \(c[1_G]\) commutes with every basis element. Thus these formulas define a unital \(k\)-algebra, including for the zero ring.
The displayed extension is additive and \(k\)-linear. Moreover \[\begin {aligned} \widehat \rho (ab)&=\sum _{g,h}a_gb_h\rho (gh)\\ &=\sum _{g,h}a_gb_h\rho (g)\rho (h) =\widehat \rho (a)\widehat \rho (b). \end {aligned}\] The \(k\)-linearity of each \(\rho (g)\) moves coefficients through it; the order of \(g,h\) is unchanged. The extension sends \([1_G]\) to \(I_M\) and \(c[1_G]\) to \(cI_M\). Every linear extension has this value on each finite basis expansion, proving uniqueness. In the regular action, \(\rho (g)\rho (h)\) first multiplies \([1_G]\) by \([h]\), then by \([g]\), giving \([gh]\). For \(g=(12),h=(23)\) in \(S_3\), this differs from \([hg]\) when \(k\ne 0\). The nonzero assumption is needed only for this distinguishing witness.
Consequently linear \(G\)-actions correspond to unital left \(k[G]\)-module structures whose restriction along \(c\mapsto c[1_G]\) is the given scalar action. Under this correspondence, a \(k\)-linear map \(f:M\to N\) is a module map exactly when \(f\rho _M(g)=\rho _N(g)f\) for every \(g\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Define \(a\cdot m=\widehat \rho (a)m\); linearity, multiplication and the unit just proved give the module laws. Conversely, restrict a \(k[G]\)-module to \(k\) and set \(\rho (g)m=[g]m\). Centrality of scalars gives \(k\)-linearity, \([g^{-1}]\) gives the inverse, and \([gh]=[g][h]\) gives the representation law. Finite distributivity shows that the two constructions are inverse. This scalar restriction is essential; an unrelated \(k\)-module structure is not being identified.
If \(f\) intertwines the group elements, finite linearity gives \[f\widehat \rho _M(a)m =\sum _g a_g f\rho _M(g)m =\sum _g a_g\rho _N(g)fm =\widehat \rho _N(a)fm.\] The converse follows by taking \(a=[g]\). This proves intertwining for every algebra element, including scalars and the unit.
[sengupta2010representations, Sections 3.1-3.2, pp. 39-41]
presents the field case, with finite support for an arbitrary group.
The proof above is the ring adaptation of
representation/module correspondence.
Mathlib's Representation.asAlgebraHom and
Representation.asAlgebraHom_single supply the linear extension
and its value on basis monomials. They do not assert that an arbitrary
faithful group action has a faithful algebra extension. For example,
\(C_2\to \mathbb R^\times \), \(r\mapsto -1\), is injective, but its
algebra extension annihilates the nonzero element \(1+[r]\).
Theorem. Projectors of an involution on a module [fdip-003O]AGENTDRAFTED
- October 29, 2026
Theorem. Projectors of an involution on a module [fdip-003O]AGENTDRAFTED
- October 29, 2026
Let \(k\) be a commutative unital ring in which \(2\) is a unit, put \(h=2^{-1}\), and let \(T:M\to M\) be linear with \(T^2=I\). The maps \(E_\varepsilon =h(I+\varepsilon T)\), for \(\varepsilon \in \{1,-1\}\), give \[\begin {aligned} E_\varepsilon ^2&=E_\varepsilon ,&E_+E_-&=E_-E_+=0,\\ E_++E_-&=I,&E_+-E_-&=T,\\ \operatorname {im}E_\varepsilon &=\ker (T-\varepsilon I)=M_\varepsilon . \end {aligned}\] Thus \(M\cong M_+\oplus M_-\), with map \(v\mapsto (E_+v,E_-v)\) and inverse addition. No finite generation, freeness or pairing is needed.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Scalar maps commute with \(T\), so \[E_\varepsilon ^2=h^2(I+2\varepsilon T+T^2) =2h^2(I+\varepsilon T)=E_\varepsilon .\] Both mixed products equal \(h^2(I-T^2)=0\); sum and difference use \(2h=1\). Also \(TE_\varepsilon =\varepsilon E_\varepsilon \). If \(Tv=\varepsilon v\), then \(E_\varepsilon v=h(v+v)=v\), proving equality of image and eigenspace. The sum identity decomposes every vector. If \(u_++u_-=0\) with \(u_\pm \in M_\pm \), applying \(E_+\) gives \(u_+=0\), and then \(u_-=0\), proving uniqueness.
If an algebra acts by \(\alpha :A\to \operatorname {End}_k(M)\), these projectors are \(A\)-linear precisely when \[T\alpha (a)=\alpha (a)T\qquad (a\in A).\] Indeed this is exactly \(A\)-linearity of \(T\); its linear combinations with \(I\) are then \(A\)-linear. Conversely, either projector recovers \(T=2E_+-I=I-2E_-\). When \(T=\alpha (\omega )\), centrality of \(\omega \) is sufficient. It need not be necessary: on \(M=\mathbb R\), let \(A=\mathbb R\times M_2(\mathbb R)\) act by \(\alpha (a,B)=aI\), and put \(\omega =(1,\operatorname {diag}(1,-1))\). Then \(\omega ^2=1\) and \(T=I\), although \(\omega \) fails to commute with a matrix unit in the second factor.
For comparison, the central-idempotent product is an algebra statement. Central orthogonal idempotents \(e_+,e_-\) with sum one give the mutually inverse unital algebra maps \[a\longmapsto (e_+a,e_-a),\qquad (x,y)\longmapsto x+y.\] Each ideal \(e_\varepsilon A\) has unit \(e_\varepsilon \) and scalar map \(c\mapsto ce_\varepsilon \). Centrality makes each component multiplicative and the mixed products zero; the sum and orthogonality identities prove both inverse equations. This is stronger than the module splitting above.
In \(k[C_2]\), writing \(g=[r]\) for \(r^2=1\), the two central idempotents are \(e_\pm =h(1\pm g)\). The explicit product is \[\begin {aligned} \Phi (a+bg)&=(a+b,a-b),\\ \Phi ^{-1}(x,y)&=h(x+y)+h(x-y)g. \end {aligned}\] The coefficient product \((a+bg)(c+dg)=(ac+bd)+(ad+bc)g\) maps to \(((a+b)(c+d),(a-b)(c-d))\). Thus \(\Phi \) is multiplicative; its inverse equations use \(2h=1\), its unit image is \((1,1)\), and scalars map diagonally. The images of \(e_+,e_-\) are \((1,0),(0,1)\). An arbitrary coefficient ring need not be semisimple, and an abstract idempotent summand need not be free.
[sengupta2010representations, Section 4.5, pp. 63-64]
discusses character projectors over a field with invertible group order;
its subsequent ideal argument assumes semisimplicity. The displayed
ring identities require only invertible two. Mathlib's
LinearMap.IsIdempotentElem.isCompl supplies the abstract
range/kernel complement. TauCeti's
TauCeti.isIdempotentElem_halfOneAdd supplies the
square-one idempotent identity, and
MonoidAlgebra.cyclicTwoEquivProd supplies the
\(C_2\) algebra product. Its generator is
\(\operatorname {Multiplicative.ofAdd}(1:\mathbb Z/2\mathbb Z)\).
None of these facts determines the ranks of a particular represented
sector; those require the coordinate bases.
Definition. The group-algebra action of the half-turn [fdip-000L]AGENTDRAFTED
- October 17, 2026
Definition. The group-algebra action of the half-turn [fdip-000L]AGENTDRAFTED
- October 17, 2026
The half-turn acts on fields before a precision or probability law is chosen. Let \(k\) be a nonzero commutative ring and \(C_2=\{1,r\}\), with \(r^2=1\). In its Group Algebra, write \(g=[r]\) and \(1=[1]\). Every element has unique coefficients \(a+bg\), and \[\begin {aligned} (a+bg)(c+dg)&=(ac+bd)\\ &\quad +(ad+bc)g. \end {aligned}\] [sengupta2010representations, Sections 3.1-3.2, pp. 39-41] gives the group basis and linear extension over a field. The ring-module extension supplies the general ring theorem; the following formulas identify its particular faithful actions.
Put \(V_k=k^4\), in vertex order \((0,1,2,3)\), and \(W_k=k^R\), with \(R=(0,2)\) in that order. Let \(\delta _i(j)=\mathbf 1_{j=i}\) be the coordinate basis of \(V_k\); let \(\delta _i^R(j)=\mathbf 1_{j=i}\) for \(i,j\in R\) be the coordinate basis of \(W_k\). These coordinate vectors differ from the real spectral vectors \(u_a\) and from the edge labels \(e_i\). The half-turn and its retained action are \[\begin {aligned} P(\phi _0,\phi _1,\phi _2,\phi _3)&=(\phi _2,\phi _3,\phi _0,\phi _1),\\ J(x_0,x_2)&=(x_2,x_0). \end {aligned}\] Applying either permutation twice returns the original coordinates, so \(P^2=I\) and \(J^2=I\). Their unique unital \(k\)-algebra extensions are \[\begin {aligned} \widehat \rho _V:k[C_2]&\longrightarrow \operatorname {End}_k(V_k),\\ \widehat \rho _V(a+bg)&=aI+bP,\\ \widehat \rho _W:k[C_2]&\longrightarrow \operatorname {End}_k(W_k),\\ \widehat \rho _W(a+bg)&=aI+bJ. \end {aligned}\] The associated left module action is \(z\cdot v=\widehat \rho _V(z)v\), and similarly on \(W_k\). Both algebra actions are faithful, meaning that their defining maps are injective.
Indeed, \(P^2=I\) gives \[\begin {aligned} (aI+bP)(cI+dP) &=(ac+bd)I\\ &\quad +(ad+bc)P. \end {aligned}\] The same calculation uses \(J^2=I\) on \(W_k\). Addition and scalar multiplication are preserved term by term, and \(1\) maps to \(I\). These facts prove the module laws. A linear extension is unique because \(1,g\) are a basis. If \(aI+bP=0\), applying it to \(\delta _0\) gives \(a\delta _0+b\delta _2=0\); coordinates \(0,2\) give \(a=b=0\). Applying \(aI+bJ\) to \(\delta _0^R\) proves injectivity on \(W_k\) in the same way. No absence of zero divisors is required.
Coordinate projection \(\pi _R(\phi )=(\phi _0,\phi _2)\) sends \(\delta _0,\delta _2\) to \(\delta _0^R,\delta _2^R\) and kills \(\delta _1,\delta _3\). Since \(\pi _RP=J\pi _R\), it intertwines the whole algebra action: \[\pi _R\widehat \rho _V(z)=\widehat \rho _W(z)\pi _R \qquad (z\in k[C_2]).\] Thus it is a \(k[C_2]\)-module map by the all-element intertwining theorem. Both coordinate faithfulness witnesses above work with zero divisors; they use more than faithfulness of the group action alone.
Suppose now that \(2\) is a unit in \(k\), and put \(h=2^{-1}\). The element \(g\) is a central involution. Its two idempotents and algebra product are \[e_+=h(1+g),\qquad e_-=h(1-g).\] Their images under the two algebra actions are the following concrete module projectors. Abstract centrality in \(k[C_2]\) supplies commutation with the represented algebra; it does not make \(P\) central in all \(\operatorname {End}_k(V_k)\).
The represented projectors are \[E_\pm =h(I\pm P),\qquad F_\pm =h(I\pm J).\] They give the eigenspace decompositions \[\begin {aligned} V_k&=V_+\oplus V_-,&V_\pm &=\operatorname {im}E_\pm ,\\ W_k&=W_+\oplus W_-,&W_\pm &=\operatorname {im}F_\pm . \end {aligned}\] For either sign \(\varepsilon \in \{1,-1\}\), the concrete half-turn sector is \[\begin {aligned} V_\varepsilon &=\{(x,y,\varepsilon x,\varepsilon y):x,y\in k\},\\ W_\varepsilon &=\{(x,\varepsilon x):x\in k\}. \end {aligned}\] Their free bases are \[\begin {aligned} b_{\varepsilon ,0}&=\delta _0+\varepsilon \delta _2,\\ b_{\varepsilon ,1}&=\delta _1+\varepsilon \delta _3,\\ c_\varepsilon &=\delta _0^R+\varepsilon \delta _2^R. \end {aligned}\] The first two coordinates of \(V_\varepsilon \), and the first coordinate of \(W_\varepsilon \), recover the coefficients uniquely. Consequently the free ranks are two and one.
To verify the splitting, \(E_++E_-=I\) gives
\(v=E_+v+E_-v\). An element in both images is fixed and annihilated
by \(E_+\), so it is zero. Further, \(PE_\varepsilon =\varepsilon
E_\varepsilon \), while \(Pv=\varepsilon v\) gives
\(E_\varepsilon v=h(v+\varepsilon Pv)=v\). This identifies the
images with the displayed coordinate sets; the proof for \(W_k\) is
identical. Mathlib's LinearMap.IsIdempotentElem.isCompl
supplies the abstract complement between an idempotent's range and
kernel. The coordinate bases and ranks above identify its concrete
summands here.
Projection respects these summands: \[\pi _RE_\varepsilon =F_\varepsilon \pi _R.\] Its restriction \(\pi _\varepsilon :V_\varepsilon \to W_\varepsilon \) sends \(b_{\varepsilon ,0}\) to \(c_\varepsilon \) and \(b_{\varepsilon ,1}\) to zero. It is surjective, with \[\ker \pi _\varepsilon =k b_{\varepsilon ,1}.\] The first coefficient of a sector vector proves the kernel formula and the displayed image of \(b_{\varepsilon ,0}\) proves surjectivity. For each sign, the square commutes, with the horizontal codomains restricted to the indicated sectors:
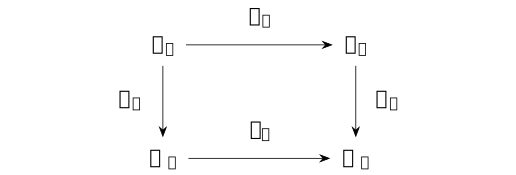
The horizontal maps select a sector; the right map removes one free coordinate within it. The algebra factors \(k\times k\), the full rank-two sectors, and the retained rank-one sectors are different levels of decomposition.
Remark. Support parity, group degree and sign sectors [fdip-003P]AGENTDRAFTED
- October 29, 2026
Remark. Support parity, group degree and sign sectors [fdip-003P]AGENTDRAFTED
- October 29, 2026
For the four-cycle over a nonzero commutative ring with invertible two, three decompositions record different structures. The support grading separates fields supported on \(\{0,2\}\) and \(\{1,3\}\). The one-step shift \(Tf(i)=f(i+1)\) exchanges these supports, so it is odd, whereas \(P=T^2\) and \(E_\pm =h(I\pm P)\) preserve them and are even. A single half-turn sign sector contains both \(b_{\varepsilon ,0}=\delta _0+\varepsilon \delta _2\) and \(b_{\varepsilon ,1}=\delta _1+\varepsilon \delta _3\), which have different support parities. A minus eigenvalue does not mean odd support.
The canonical group grading of \(k[C_2]\) has components \(k\,1\) of degree \(1_G\) and \(k\,g\) of degree \(r\). Their multiplication follows the group law, in particular \(g^2=1\). Over a ring these are rank-one free summands. The representation sends \(g\) to support-even \(P\); it therefore does not preserve these particular gradings under \(r\mapsto 1\in \mathbb Z/2\mathbb Z\). The projector ideals are different again: \(e_-^2=e_-\ne 0\), while an odd homogeneous component would have its square in the even component. The direct product, the group grading and the support grading cannot be interchanged. These are the distinct splitting levels applied to the concrete action.
The ordinary adjoint uses the counting pairing \(b(f,u)=\sum _i f_i u_i\), with identity coefficient involution. Delta vectors recover all coefficients, so the pairing is perfect. Reindexing a finite sum shows that every permutation action is an isometry, hence \[b(\rho (\sigma )f,u)=b(f,\rho (\sigma ^{-1})u).\] Uniqueness of the ordinary adjoint gives \(\rho (\sigma )^\dagger =\rho (\sigma ^{-1})\); in particular \(T^\dagger =T^{-1}\) and \(P^\dagger =P\). There is no complex conjugation or Koszul sign in this calculation.
The corresponding ordinary group-algebra operation is \[\left (\sum _g a_g[g]\right )^*=\sum _g a_g[g^{-1}].\] It is \(k\)-linear, fixes scalars, squares to the identity and reverses products, since \((gh)^{-1}=h^{-1}g^{-1}\) and all sums are finite. For an isometric representation with a perfect pairing, taking the adjoint of its finite linear extension therefore gives \(\widehat \rho (z^*)=\widehat \rho (z)^\dagger \). The isometry premise matters: the infinite cyclic group acting on \(\mathbb R\) by multiplication by \(2\) has adjoint \(2\) and inverse \(1/2\), so this identity fails for that representation. The counting action satisfies the premise.
The group basis and inversion are as in [sengupta2010representations, Sections 3.1-3.2, pp. 39-41]; the grading and adjoint comparisons above are direct calculations. The shift calculation supplies the support-degree and adjoint identities. Clifford parity of a quadratic quotient is a further structure; these ordinary formulas introduce neither a graded star nor a Hermitian extension.
Theorem. The real Gaussian law is a product over orthogonal sectors [fdip-000M]AGENTDRAFTED
- October 17, 2026
Theorem. The real Gaussian law is a product over orthogonal sectors [fdip-000M]AGENTDRAFTED
- October 17, 2026
Let \(H\) be a finite-dimensional real inner-product space, \(P:H\to H\) an orthogonal involution, and \(Q:H\to H\) a positive self-adjoint precision with \(QP=PQ\). Put \(H_\varepsilon =\ker (P-\varepsilon I)\) and \(E_\varepsilon =(I+\varepsilon P)/2\). Use induced Euclidean volumes on the uncompleted Borel sigma-algebras. The restrictions \(Q_\varepsilon =Q|_{H_\varepsilon }\) are positive self-adjoint. For their Gaussian laws, \[\begin {aligned} D:H&\longrightarrow H_+\times H_-,\\ z&\longmapsto (E_+z,E_-z),\\ D_*\mu _Q&=\mu _{Q_+}\otimes \mu _{Q_-},\qquad Z_Q=Z_{Q_+}Z_{Q_-}. \end {aligned}\] Thus the sector-valued random variables \(E_+,E_-\) are independent with the indicated marginal laws. The four-cycle recovery computes both blocks, their normalizers and their retained scalar laws explicitly.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The module projector identities give the direct sum. For \(u\in H_+\), \(v\in H_-\), orthogonality of \(P\) gives \(\langle u,v\rangle =\langle Pu,Pv\rangle =-\langle u,v\rangle \), so \(\langle u,v\rangle =0\). Addition \(J:H_+\times H_-\to H\), \(J(u,v)=u+v\), is therefore an isometric linear isomorphism with inverse \(D\). Commutation gives \(PQu=QPu=\varepsilon Qu\) for \(u\in H_\varepsilon \); hence \(Q\) preserves each sector. Restricting its pairing identity and testing nonzero sector vectors proves self-adjointness and positivity of \(Q_\varepsilon \).
Concatenating orthonormal bases of \(H_+,H_-\) gives an orthonormal basis of \(H\). Coordinate product Lebesgue measure, transported by these charts, therefore proves \[J_*(\lambda _+\otimes \lambda _-)=\lambda _H,\qquad D_*\lambda _H=\lambda _+\otimes \lambda _-.\] This is precisely orthogonal product volume. Finite-dimensional spaces have countable bases, so the product Borel sigma-algebra is the Borel sigma-algebra of the product. Bounded coordinate cubes exhaust each space, proving sigma-finiteness. A zero-dimensional sector has unit mass on its sole point.
Orthogonality and preservation of sectors give the action identity \[\langle u+v,Q(u+v)\rangle =\langle u,Q_+u\rangle +\langle v,Q_-v\rangle .\] For \(w_Q(z)=e^{-\langle z,Qz\rangle/2}\), this says \(w_Q(J(u,v))=w_{Q_+}(u)w_{Q_-}(v)\). The positive normalizer theorem applies separately to all three positive self-adjoint maps: \[Z_R=\frac {(2\pi )^{\dim U/2}}{\sqrt {\det R}}\in (0,\infty ) \quad (R=Q,Q_+,Q_-\text { on its space }U).\] Its proof uses positive eigenvalues, the scalar Gaussian integral and nonnegative Tonelli, without presupposing this product law. Empty determinants and normalizers are one. Applying Tonelli with the volume and weight identities just proved gives \(Z_Q=Z_{Q_+}Z_{Q_-}\).
For Borel sets \(A_+\subseteq H_+\), \(A_-\subseteq H_-\), all the following integrands are nonnegative measurable functions: \[\begin {aligned} (D_*\mu _Q)(A_+\times A_-) &=\frac {1}{Z_{Q_+}Z_{Q_-}}\\ &\quad \cdot \int _{A_+\times A_-}w_{Q_+}(u)w_{Q_-}(v) \,d(\lambda _+\otimes \lambda _-)(u,v)\\ &=\mu _{Q_+}(A_+)\mu _{Q_-}(A_-). \end {aligned}\] Rectangles form a pi-system containing the whole product and generating its Borel sigma-algebra. The pi-lambda uniqueness theorem for finite measures identifies the two probability measures everywhere. Their coordinate marginals and the displayed rectangle equation are exactly independence of \(E_+,E_-\). The argument also covers a zero sector, whose law is deterministic. Algebraic splitting alone would not have supplied this probability identity.
For the actual polynomial function algebras, write \(\omega _R(p)=\int p\,d\mu _R\). Then \[\omega _Q\bigl ((p_+\circ E_+)(p_-\circ E_-)\bigr ) =\omega _{Q_+}(p_+)\omega _{Q_-}(p_-).\] Indeed linear precomposition takes polynomial generators to polynomial generators. Every polynomial, product and square has finite absolute Gaussian integral by Proposition [fdip-002W], applied on the full space and on each sector. Tonelli applied first to the absolute product therefore justifies signed Fubini, which gives the formula from the product law. These are real polynomial states: they are linear, normalized and nonnegative on \(p^2\), with the identity star. No algebra structure on all integrable functions, or state on \(\operatorname {End}(H)\), is being used.
[friedli2017statistical, Proposition B.55, p. 505] uses covariance as its positive parameter. In an orthonormal chart, set \(\Sigma =Q^{-1}\). Its eigenvalues are positive, \(\Sigma ^{-1}=Q\) and \(\det \Sigma =(\det Q)^{-1}\), so its normalized density is exactly \(Z_Q^{-1}w_Q\). The inverse-precision covariance theorem identifies \(\Sigma \) as the covariance. The product proof above uses densities, not an inference from zero covariance for an unspecified law.
Mathlib's OrthonormalBasis.measurePreserving_repr
supports passage to orthonormal coordinates. Index coordinates by the
disjoint union of orthonormal bases of \(H_+\) and \(H_-\). Then
\(\Sigma =\operatorname {diag}(Q_+^{-1},Q_-^{-1})\) is positive
definite, hence positive semidefinite, with zero cross block and mean
zero. After the density identification, TauCeti's
TauCeti.Probability.indepFun_sumEquivProd_multivariateGaussian_iff
gives the corresponding coordinate independence. It concerns this
Gaussian covariance, not an arbitrary algebraic splitting or Schur
fiber integral.
The integration convention is [tao2011measure, Theorem 1.7.15, pp. 200-201, preliminary version]. All probability assertions here are finite-dimensional and real, with strictly positive precision and specified volume. They supply no Lebesgue probability over a general coefficient ring; a singular precision needs a separately specified constrained space and law.
Proposition. Restricting a split Schur map to sign sectors [fdip-003Q]AGENTDRAFTED
- October 29, 2026
Proposition. Restricting a split Schur map to sign sectors [fdip-003Q]AGENTDRAFTED
- October 29, 2026
Let \(k\) be a commutative unital ring with invertible two and \(H=X\oplus Y\). Let \(P=P_X\oplus P_Y\), where \(P_X^2=I_X\), \(P_Y^2=I_Y\), and let \(Q:H\to H\) commute with \(P\). Write the typed split components as \[\begin {aligned} A&:X\to X,&B&:Y\to X,\\ E&:X\to Y,&C&:Y\to Y,\\ Q(x,y)&=(Ax+By,Ex+Cy). \end {aligned}\] If \(C\) is invertible, the split Schur map \(S=A-BC^{-1}E\) preserves both sign sectors of \(P_X\), and \[S|_{X_\varepsilon } =A_\varepsilon -B_\varepsilon C_\varepsilon ^{-1}E_\varepsilon .\] Here \(X_\varepsilon =\ker (P_X-\varepsilon I)\), \(Y_\varepsilon =\ker (P_Y-\varepsilon I)\), and each subscript means restriction to the indicated source and target sectors.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Evaluate \(QP=PQ\) on \((x,0)\) and \((0,y)\) and project to both summands. This gives \[\begin {aligned} AP_X&=P_XA,&BP_Y&=P_XB,\\ EP_X&=P_YE,&CP_Y&=P_YC. \end {aligned}\] Multiplying the last identity on both sides by the inverse of \(C\) gives \(C^{-1}P_Y=P_YC^{-1}\). Each of these identities proves that its map takes sign-\(\varepsilon \) vectors to sign-\(\varepsilon \) vectors. In particular \(C_\varepsilon \) is invertible, with inverse \(C^{-1}|_{Y_\varepsilon }\), since the two inverse equations restrict to the sector. Finally \[\begin {aligned} SP_X&=AP_X-BC^{-1}EP_X\\ &=P_XA-BP_YC^{-1}E=P_XS. \end {aligned}\] Restricting the actual composite \(BC^{-1}E:X\to X\) now gives exactly the asserted formula, with no interchange of differently typed factors.
This is the sign-sector specialization of Schur transport, using the module projectors. Its block convention agrees with [boyd2004convex, Appendix A.5.5, pp. 650-651] after exchanging the source's first pivot to \(C\). The proof here is over modules; no pairing, self-adjointness, stationary field or probability law has been assumed. If the prescribed splitting is not preserved by \(P\), the required \(P_X,P_Y\) and these restrictions are not supplied.
Theorem. Gaussian marginalization commutes with sector decomposition [fdip-003R]AGENTDRAFTED
- October 29, 2026
Theorem. Gaussian marginalization commutes with sector decomposition [fdip-003R]AGENTDRAFTED
- October 29, 2026
Let \(H=X\mathbin \perp Y\) be a finite-dimensional real orthogonal sum, \(P=P_X\oplus P_Y\) an orthogonal involution, and \(Q\) a positive self-adjoint precision commuting with \(P\). Use induced Euclidean volumes and Borel Gaussian laws. For \(Q(x,y)=(Ax+By,B^\dagger x+Cy)\), put \(S=A-BC^{-1}B^\dagger \). The sign sectors are \(H_\varepsilon =X_\varepsilon \mathbin \perp Y_\varepsilon \). Let \(\pi (x,y)=x\) and let \(\pi _\varepsilon \) be its sector restriction. The typed restriction identity gives \[S_\varepsilon :=S|_{X_\varepsilon } =A_\varepsilon -B_\varepsilon C_\varepsilon ^{-1} B_\varepsilon ^\dagger .\] Then the following square commutes both for maps and for their pushforwards of the Gaussian laws:
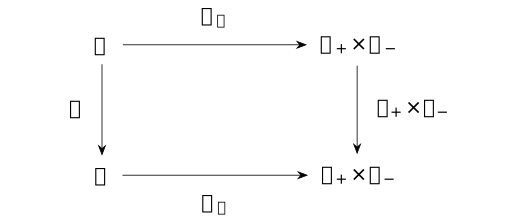
Here \(D_H(z)=(E_+z,E_-z)\) and \(D_X(x)=(F_+x,F_-x)\) are the orthogonal sector decompositions. The full retained law is \(\pi _*\mu _Q=\mu _S\); both routes give \(\mu _{S_+}\otimes \mu _{S_-}\) on \(X_+\times X_-\).
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Testing positivity on \((0,y)\) makes \(C\) positive and invertible. Its inverse is self-adjoint by adjointing both inverse equations, so \(S\) is self-adjoint. With \(K=C^{-1}B^\dagger \), expansion gives \[\langle (x,y),Q(x,y)\rangle =\langle x,Sx\rangle +\langle y+Kx,C(y+Kx)\rangle .\] The two cross terms sum to \(2\langle x,By\rangle \); the last \(K\)-term cancels the subtraction in \(S\). Testing on \((x,-Kx)\) proves \(S>0\). Thus the hypotheses of positive Gaussian elimination hold. For every fixed \(x\), translation by \(Kx\) preserves induced volume, giving the pointwise fiber identity \[\int _Y e^{-\langle (x,y),Q(x,y)\rangle/2}\,d\lambda _Y(y) =Z_C e^{-\langle x,Sx\rangle/2}.\] The normalizer is \(Z_C=(2\pi )^{\dim Y/2}/\sqrt {\det C}\). Nonnegative Tonelli gives \(Z_Q=Z_CZ_S\), and inserting a Borel indicator of \(x\) then dividing proves \(\pi _*\mu _Q=\mu _S\). This is the retained marginal theorem, with its actual volume and positive finite normalizers.
The restricted \(Q_\varepsilon ,C_\varepsilon ,S_\varepsilon \) are positive self-adjoint. Applying the same fiber identity within \(H_\varepsilon \) gives, for every \(x_\varepsilon \), \[\begin {aligned} &\int _{Y_\varepsilon } e^{-\langle (x_\varepsilon ,y),Q_\varepsilon (x_\varepsilon ,y)\rangle/2} \,d\lambda _{Y_\varepsilon }(y)\\ &\qquad =Z_{C_\varepsilon } e^{-\langle x_\varepsilon ,S_\varepsilon x_\varepsilon \rangle/2}. \end {aligned}\] Hence \((\pi _\varepsilon )_*\mu _{Q_\varepsilon }=\mu _{S_\varepsilon }\). The orthogonal product theorem, applied to \(Q,C,S\), gives their product laws and \(Z_C=Z_{C_+}Z_{C_-}\). No scalar factor is discarded before normalization.
Since \(\pi P=P_X\pi \), the projector formulas imply \(\pi E_\varepsilon =F_\varepsilon \pi \), proving the map square. Pushforwards compose by inverse images. The upper route first gives \(\mu _{Q_+}\otimes \mu _{Q_-}\). Its pushforward by \(\pi _+\times \pi _-\) agrees with \(\mu _{S_+}\otimes \mu _{S_-}\) on every Borel rectangle, using the sector marginal identities, and therefore everywhere by uniqueness of probability measures on the rectangle-generated Borel sigma-algebra. The lower route first gives \(\mu _S\); its sector decomposition gives the same product.
Pullback on the polynomial function algebras reverses all 4 arrows. For every polynomial \(f\) on \(X_+\times X_-\), the commuting map square gives \[f\circ D_X\circ \pi =f\circ (\pi _+\times \pi _-)\circ D_H.\] Precomposition by each linear map is a unital algebra homomorphism, as in polynomial transport. For a polynomial \(p\in \operatorname {Pol}(X)\), nonnegative integration first gives \(\int |p\circ \pi |\,d\mu _Q=\int |p|\,d\mu _S\); absolute Gaussian moments make both sides finite for polynomials. Subtraction of positive and negative parts then gives \(\omega _S=\omega _Q\circ \pi ^*\) and the corresponding equalities on every side of the square. This is equality of normalized polynomial functionals, in addition to maps and probability laws.
The specified conditional kernel at eliminated field zero instead has precision \(A\); it need not equal the marginal of precision \(S\). If \(B=0\), then \(S=A\), so equality can occur. The coupled cycle gives a concrete difference. A nonstable retained set does not supply this square: for retention \(\{0,1\}\), \(\pi \delta _2=0\) but \(\pi P\delta _2=\delta _0\). A singular eliminated direction can have infinite fiber integral, as for \(Q(x,y)=(x,0)\) on \(\mathbb R^2\). A pseudoinverse does not make that integral finite. The massless cycle has a constant zero mode and requires a separately specified constrained law.
The Schur convention is [boyd2004convex, Appendix A.5.5, pp. 650-651], with the pivot exchanged to \(C\). The Gaussian density convention is [friedli2017statistical, Proposition B.55, p. 505], where covariance is \(\Sigma =Q^{-1}\). The sector square is the direct combination proved above; the formalization references discussed with the retained marginal theorem support Gaussian images and signed Fubini with their stated hypotheses, not the pointwise fiber constants.
Example. The complete sector law of the alternating four-cycle [fdip-003S]AGENTDRAFTED
- October 29, 2026
Example. The complete sector law of the alternating four-cycle [fdip-003S]AGENTDRAFTED
- October 29, 2026
For the alternating four-cycle with \(t,m>0\), the two real half-turn sectors are independent under the Gaussian law. Their precision and covariance blocks vary with \(t,m\), although the action and its projectors do not. Put \(a=m^2\) and \(s=1+t+a\). The counting quadratic form is \[\begin {aligned} \langle \phi ,Q\phi \rangle &=(\phi _1-\phi _0)^2+t(\phi _2-\phi _1)^2\\ &\quad +(\phi _3-\phi _2)^2+t(\phi _0-\phi _3)^2 +a\sum _i\phi _i^2. \end {aligned}\] It is strictly positive for nonzero \(\phi \), since \(a>0\). The weighted incidence construction is self-adjoint, and the half-turn reindexes the 4 edge terms without changing their weights. Thus \(QP=PQ\), as required by the intrinsic product law. In vertex order \((0,1,2,3)\), the massive precision is \[Q=\begin {pmatrix} s&-1&0&-t\\-1&s&-t&0\\0&-t&s&-1\\-t&0&-1&s \end {pmatrix}.\] Use the orthonormal vectors \[\begin {aligned} v_{\varepsilon ,0}&=(\delta _0+\varepsilon \delta _2)/\sqrt 2,\\ v_{\varepsilon ,1}&=(\delta _1+\varepsilon \delta _3)/\sqrt 2, \qquad \varepsilon \in \{1,-1\}. \end {aligned}\] Write \(\phi =\sum _\varepsilon (x_\varepsilon v_{\varepsilon ,0}+y_\varepsilon v_{\varepsilon ,1})\) and \(z_\varepsilon =(x_\varepsilon ,y_\varepsilon )\). These are normalized sector coordinates, rather than the coefficients in the unnormalized free bases of Definition [fdip-000L]. In particular \[\begin {aligned} \phi _0&=(x_++x_-)/\sqrt 2,&\phi _2&=(x_+-x_-)/\sqrt 2,\\ \phi _1&=(y_++y_-)/\sqrt 2,&\phi _3&=(y_+-y_-)/\sqrt 2. \end {aligned}\]
In the order \((v_{+,0},v_{+,1},v_{-,0},v_{-,1})\), the precision is \(\operatorname {diag}(Q_+,Q_-)\) and its inverse is \(\operatorname {diag}(G_+,G_-)\), where \[\begin {aligned} Q_+&=\begin {pmatrix}s&-(1+t)\\-(1+t)&s\end {pmatrix},\\ Q_-&=\begin {pmatrix}s&t-1\\t-1&s\end {pmatrix},\\ G_+&=\tfrac 1{a(a+2+2t)} \begin {pmatrix}s&1+t\\1+t&s\end {pmatrix},\\ G_-&=\tfrac 1{(a+2)(a+2t)} \begin {pmatrix}s&1-t\\1-t&s\end {pmatrix}. \end {aligned}\] The covariance in these coordinates is given by the displayed inverse blocks. If \(T\phi =(z_+,z_-)\), then \[T_*\mu _Q=\mu _{Q_+}\otimes \mu _{Q_-}.\] The product on the right is the product probability measure. In particular the sector random vectors \(z_+,z_-\) are independent.
[friedli2017statistical, Proposition B.55, p. 505] gives the Gaussian covariance and coordinate-change convention. The positive Gaussian normalization and inverse-precision covariance apply to each block. The product assertion follows from the explicit density calculation below, rather than from the algebraic direct sum alone.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
Each unnormalized vector has squared norm two, and the pairings between distinct vectors are zero. Thus the basis matrix \(O\) with the displayed columns is orthogonal, \(T=O^T\), and \(|\det O|=1\). Applying \(Q\) gives \[\begin {aligned} Qv_{+,0}&=sv_{+,0}-(1+t)v_{+,1},\\ Qv_{+,1}&=-(1+t)v_{+,0}+sv_{+,1},\\ Qv_{-,0}&=sv_{-,0}+(t-1)v_{-,1},\\ Qv_{-,1}&=(t-1)v_{-,0}+sv_{-,1}. \end {aligned}\] These are precisely the two asserted blocks. Their sum and difference vectors have eigenvalues \[\begin {aligned} Q_+&:\quad a,\ a+2+2t,\\ Q_-&:\quad a+2t,\ a+2. \end {aligned}\] They are all positive. Multiplication by the displayed \(G_\pm \) gives the identity: the diagonal numerators are respectively \(s^2-(1+t)^2=a(a+2+2t)\) and \(s^2-(t-1)^2=(a+2)(a+2t)\), and the off-diagonal numerators vanish. This proves the inverse formulas.
The orthogonal change of variables preserves coordinate Lebesgue measure and writes the Euclidean action as \[\mathcal A(\phi )=\tfrac 12 z_+^TQ_+z_+ +\tfrac 12 z_-^TQ_-z_-.\] Each factor has a finite positive normalizer \[Z_\pm =\frac {2\pi }{\sqrt {\det Q_\pm }}.\] Tonelli's theorem applied to the nonnegative density gives \(Z_Q=Z_+Z_-\). Division by this product yields the product of the two normalized densities. Integrating over every Borel rectangle \(A_+\times A_-\) gives \[\begin {aligned} &\mu _Q\{z_+\in A_+,\ z_-\in A_-\}\\ &\qquad =\mu _{Q_+}(A_+)\mu _{Q_-}(A_-). \end {aligned}\] Rectangles generate the product Borel sigma-algebra, so uniqueness of probability measures identifies the product law and proves independence. In particular it does not assume that zero covariance alone implies independence. Polynomial moments are integrable by Proposition [fdip-002W].
Writing \[\begin {aligned} d_+&=a(a+2+2t),&d_-&=(a+2)(a+2t),\\ \Delta &=d_+d_-=a(a+2)(a+2t)(a+2+2t)>0, \end {aligned}\] the full normalizer is \(Z_Q=4\pi ^2/\sqrt \Delta \).
Retain \(R=(0,2)\). Its orthonormal sector vectors are \[w_\varepsilon =(\delta _0^R+\varepsilon \delta _2^R)/\sqrt 2.\] The projection satisfies \[\begin {aligned} \pi _Rv_{\varepsilon ,0}&=w_\varepsilon ,\\ \pi _Rv_{\varepsilon ,1}&=0. \end {aligned}\] Thus the retained sector coordinates are exactly \(x_+,x_-\), with no additional factor of \(\sqrt 2\). In these coordinates, the retained precision has positive scalar blocks \[\begin {aligned} \sigma _+&=s-\frac {(1+t)^2}{s} =\frac {a(a+2+2t)}s,\\ \sigma _-&=s-\frac {(t-1)^2}{s} =\frac {(a+2)(a+2t)}s. \end {aligned}\] The retained coordinates are independent centered Gaussians with variances \(\sigma _+^{-1},\sigma _-^{-1}\). Decomposing into sectors and taking this marginal therefore give the same law in either order, as in the map and measure square.
Proof.
- October 29, 2026
Proof.
- October 29, 2026
A sector has precision \(\begin {pmatrix}s&c\\c&s\end {pmatrix}\), with \(c=-(1+t)\) or \(c=t-1\). Complete the square: \[\begin {aligned} sx^2+2cxy+sy^2 &=s(y+cx/s)^2\\ &{}+(s-c^2/s)x^2. \end {aligned}\] The scalar Gaussian integral gives \[\begin {aligned} &\int _{\mathbb R} e^{-(sx^2+2cxy+sy^2)/2}\,dy\\ &\qquad =\sqrt {\frac {2\pi }{s}} e^{-(s-c^2/s)x^2/2}. \end {aligned}\] Each eliminated sector coordinate contributes \(\sqrt {2\pi/s}\); the two factors multiply to \(2\pi/s\). This is exactly the factor for the original eliminated block \(C=sI_2\) in Example [fdip-000F]. The retained orthogonal change of coordinates also has absolute determinant one. Normalizing the two scalar densities proves the claimed retained product law.
Equivalently, in retained/eliminated vertex order \(X=(0,2)\), \(Y=(1,3)\), the typed arrays are \[A=C=sI_2,\qquad B=E^T=-\begin {pmatrix}1&t\\t&1\end {pmatrix}.\] Thus \(BC^{-1}E=s^{-1}\begin {pmatrix}1+t^2&2t\\2t&1+t^2\end {pmatrix}\), and the effective precision in vertex coordinates is \[\begin {aligned} S&=\begin {pmatrix}\alpha &-\beta \\-\beta &\alpha \end {pmatrix},\\ \alpha &=s-\frac {1+t^2}{s},\qquad \beta =\frac {2t}{s}. \end {aligned}\] It acts on \(w_+\) by \(\alpha -\beta =\sigma _+\), and on \(w_-\) by \(\alpha +\beta =\sigma _-\). Thus each sector's Schur complement agrees with the corresponding block of \(S\).
Direct multiplication also gives \[\begin {aligned} S^{-1}&=\frac {1}{\alpha ^2-\beta ^2} \begin {pmatrix}\alpha &\beta \\\beta &\alpha \end {pmatrix},\\ \alpha ^2-\beta ^2&=\sigma _+\sigma _-=\Delta/s^2>0,\\ Z_S&=\frac {2\pi }{\sqrt {\sigma _+\sigma _-}} =\frac {2\pi s}{\sqrt \Delta }. \end {aligned}\] The full eliminated factor \(2\pi/s\) times \(Z_S\) is exactly \(Z_Q\); both the pointwise fiber constants and the normalized law agree.
See [boyd2004convex, Appendix A.5.5, pp. 650-651] for the general block formula. Restricting \(Q\) to a full sector still leaves two coordinates. Integrating out its second coordinate takes the Schur complement computed above.
Transforming the retained coordinates back gives \[\begin {aligned} \operatorname {Var}(\phi _0) =\operatorname {Var}(\phi _2) &=\tfrac 12(\sigma _+^{-1}+\sigma _-^{-1}),\\ \langle \phi _0\phi _2\rangle _Q &=\tfrac 12(\sigma _+^{-1}-\sigma _-^{-1}). \end {aligned}\] For \(m=t=1\), the sector blocks and their inverses are \[\begin {aligned} Q_+&=\begin {pmatrix}3&-2\\-2&3\end {pmatrix},&Q_-&=3I_2,\\ G_+&=\tfrac 15\begin {pmatrix}3&2\\2&3\end {pmatrix},&G_-&=I_2/3. \end {aligned}\] Hence \(\sigma _+=5/3\), \(\sigma _-=3\); the retained variance is \(7/15\) and the cross covariance is \(2/15\). Directly, \[\begin {aligned} S&=\tfrac 13\begin {pmatrix}7&-2\\-2&7\end {pmatrix},& S^{-1}&=\tfrac 1{15}\begin {pmatrix}7&2\\2&7\end {pmatrix},\\ Z_Q&=\frac {4\pi ^2}{3\sqrt 5},&Z_S&=\frac {2\pi }{\sqrt 5}. \end {aligned}\] The eliminated factor is \(2\pi/3\). The specified conditional kernel at eliminated field zero instead gives precision \(A=3I_2\) and covariance \(I_2/3\), whose zero cross covariance differs from \(2/15\). For \(m=1,t=2\), \[\begin {aligned} Q_+&=\begin {pmatrix}4&-3\\-3&4\end {pmatrix},\\ Q_-&=\begin {pmatrix}4&1\\1&4\end {pmatrix},\\ G_+&=\tfrac 17\begin {pmatrix}4&3\\3&4\end {pmatrix},\\ G_-&=\tfrac 1{15}\begin {pmatrix}4&-1\\-1&4\end {pmatrix}. \end {aligned}\] Now \(\sigma _+=7/4\), \(\sigma _-=15/4\); the retained variance is \(44/105\) and the cross covariance is \(16/105\). Here \[\begin {aligned} S&=\begin {pmatrix}11/4&-1\\-1&11/4\end {pmatrix},\\ S^{-1}&=\tfrac 1{105}\begin {pmatrix}44&16\\16&44\end {pmatrix},\\ Z_Q&=\frac {4\pi ^2}{\sqrt {105}},&Z_S&=\frac {8\pi }{\sqrt {105}}. \end {aligned}\] The eliminated factor is \(\pi/2\). Both examples have the same \(P,J,E_\pm ,F_\pm \), but different covariance matrices and hence different Gaussian states: their polynomial functionals differ on \(\phi _0\phi _2\).
The half-turn commutant explains why these two-dimensional precision blocks may mix coordinates while respecting the same symmetry.
Mathlib's OrthonormalBasis.measurePreserving_repr
supplies the volume-preserving passage to orthonormal coordinates.
TauCeti's
TauCeti.Probability.indepFun_sumEquivProd_multivariateGaussian_iff
characterizes independence of complementary coordinate blocks by
vanishing cross covariance. Index each sector by \(\{0,1\}\) and
the full coordinates by the disjoint union of these sets. Take mean
zero and covariance \(\Sigma =\operatorname {diag}(G_+,G_-)\).
The positive eigenvalues above make \(\Sigma \) positive definite,
hence positive semidefinite, and its cross block is zero.
After identifying the normalized sector density with this Gaussian
law, the theorem gives independence. The formalization references discussed
with the inverse-precision covariance theorem use
\(G_\pm =Q_\pm ^{-1}\) as their parameters. The concrete matrices,
density identification and sectorwise Schur calculation are supplied
by the proofs above.
Proposition. The half-turn commutant permits mixing within a sector [fdip-003T]AGENTDRAFTED
- October 29, 2026
Proposition. The half-turn commutant permits mixing within a sector [fdip-003T]AGENTDRAFTED
- October 29, 2026
For the real half-turn, define its commutant by \(\operatorname {Comm}(P)=\{R\in \operatorname {End}_{\mathbb R}(V):RP=PR\}\). Restriction to the two sectors gives an algebra isomorphism \[\operatorname {Comm}(P) \cong \operatorname {End}(V_+)\times \operatorname {End}(V_-) \cong M_2(\mathbb R)\times M_2(\mathbb R).\] If \(R\) commutes with \(P\) and \(Pv=\varepsilon v\), then \(PRv=RPv=\varepsilon Rv\), so it preserves each sector. Conversely, a map preserving both sectors obeys \(PR(v_++v_-)=Rv_+-Rv_-=RP(v_++v_-)\). The inverse to restriction acts separately on the unique sector components; composition and the unit are componentwise. The explicit bases identify each endomorphism algebra with \(M_2(\mathbb R)\).
In sector coordinates \(P=\operatorname {diag}(I_2,-I_2)\). For \(R=\begin {pmatrix}A&B\\C&D\end {pmatrix}\), direct comparison gives \[RP=PR\quad \Longleftrightarrow \quad 2B=2C=0 \quad \Longleftrightarrow \quad B=C=0.\] The group-algebra image is the strictly smaller algebra \[\{\operatorname {diag}(xI_2,yI_2):x,y\in \mathbb R\}.\] Indeed \(aI+bP\) has \(x=a+b\), \(y=a-b\), and every pair is obtained from \(a=(x+y)/2\), \(b=(x-y)/2\). The map swapping \(b_{+,0},b_{+,1}\) and vanishing on \(V_-\) belongs to the commutant but is not scalar on \(V_+\), proving strict containment.
Each sign occurs twice, so an operator commuting with \(P\) may mix the two vectors in either sector. Symmetry therefore does not force \(Q_\pm \) to be scalar; the cycle precision blocks exhibit the freedom explicitly. The group-algebra/module convention comes from [sengupta2010representations, Sections 3.1-3.2, pp. 39-41]; the commutant calculation is direct. The interpretation boundary remains: this finite algebra calculation selects no continuous gauge group, physical mass spectrum or interaction.
Example. The half-turn in characteristic two [fdip-000N]AGENTDRAFTED
- October 17, 2026
Example. The half-turn in characteristic two [fdip-000N]AGENTDRAFTED
- October 17, 2026
The coefficient assumption in the two-sector decomposition is essential. Let \(k\) now be a nonzero commutative ring of characteristic two. Use the same \(C_2\), group-basis element \(g\), coordinate modules \(V_k,W_k\), and maps \(P,J\). The faithful algebra actions still exist, but the algebra is \[k[C_2]\cong k[z]/(z^2),\] and its idempotents are exactly the scalar idempotents of \(k\). In particular, if \(k\) is a field, it has no idempotents other than \(0,1\), so it cannot be isomorphic to \(k\times k\).
The Group Algebra still has its group basis, as in [sengupta2010representations, Sections 3.1-3.2, pp. 39-41]. The character projectors in [sengupta2010representations, Section 4.5, p. 63] require the group order to be invertible in the field. The following calculation identifies what replaces that product when the order is zero in \(k\).
Proof.
- October 17, 2026
Proof.
- October 17, 2026
Put \(\eta =g-1\). Its coefficient at \(g\) is \(1\), so \(\eta \ne 0\); nevertheless \[\eta ^2=g^2-2g+1=0.\] Since \(g=1+\eta \), the pair \(1,\eta \) is a basis: \[c+d\eta =(c-d)+dg,\] so coefficient comparison proves independence as well as spanning. Evaluation at \(\eta \) therefore induces a unital \(k\)-algebra map \[\begin {aligned} \Psi :k[z]/(z^2)&\longrightarrow k[C_2],\\ [f(z)]&\longmapsto f(\eta ). \end {aligned}\] It is well defined because \(\eta ^2=0\). Every polynomial has a unique remainder \(c+dz\) modulo the monic polynomial \(z^2\): write \(f=c+dz+z^2q\), and observe that a multiple of \(z^2\) has zero constant and linear coefficients. Hence the quotient has basis \([1],[z]\), even when \(k\) has zero divisors. The map sends it to the basis \(1,\eta \), so it is bijective, with inverse \(a+bg\mapsto [(a+b)+bz]\). Evaluation and its inverse preserve the unit and scalars. The algebra \(k[z]/(z^2)\) is the algebra of dual numbers over \(k\); its nonzero element \([z]\) has square zero.
If \(c+d\eta \) is idempotent, commutativity and characteristic two give \[(c+d\eta )^2=c^2.\] Comparison in the basis \(1,\eta \) forces \(d=0\) and \(c^2=c\); conversely every such scalar is idempotent. If \(k\) is a field, or more generally has no zero divisors, \(c(c-1)=0\) implies \(c=0\) or \(c=1\). Both are idempotent. In contrast, \((1,0)\) is a nonzero idempotent different from the unit in \(k\times k\). An algebra isomorphism preserves these properties, which rules out the product. The field hypothesis matters: a general characteristic-two ring can already have nontrivial scalar idempotents. For example \(k=\mathbb F_2\times \mathbb F_2\) has 4 scalar idempotents, including \((1,0)\) and \((0,1)\); all 4 remain idempotent in \(k[z]/(z^2)\). Thus the assertion of exactly two idempotents does not extend to every characteristic-two ring, nor does it rule out all product decompositions in that generality.
On the vertex module, the same half-turn still satisfies \(P^2=I\), while \(-1=1\). Its two proposed eigenspaces now coincide: \[\begin {aligned} \ker (P-I)&=\ker (P+I)\\ &=\{(x,y,x,y):x,y\in k\}. \end {aligned}\] Its coordinate basis is \(\delta _0+\delta _2,\delta _1+\delta _3\): coordinates zero and one recover the coefficients. It is free of rank two (dimension two over a field); adding it to itself does not recover the full module, because \(\delta _0\) is not in it. On the retained module, \[\begin {aligned} \ker (J-I)&=\ker (J+I)\\ &=\{(x,x):x\in k\}, \end {aligned}\] whose basis is \(\delta _0^R+\delta _2^R\), with its coefficient recovered at zero. It has free rank one, and dimension one over a field. These equalities follow directly from the coordinate formulas for \(P,J\).
The nonzero nilpotent is visible in the faithful action as well. For \(N=P-I\), \[\begin {aligned} N^2&=P^2-2P+I=0,\\ N\delta _0&=\delta _2-\delta _0\ne 0. \end {aligned}\] The last vector has coefficient \(1\) at coordinate \(2\). Similarly, \(J-I\) is nonzero on \(\delta _0^R\) and has square zero: \((J-I)\delta _0^R=\delta _2^R-\delta _0^R\ne 0\). Both coordinate injectivity proofs for the algebra actions in Definition [fdip-000L] still apply. Thus the nilpotent \(\eta \) has a faithful nonzero action on both modules. The expressions \((I\pm P)/2\) and \((I\pm J)/2\) are undefined because \(2=0\). The action and projection intertwiner survive, but the complementary projectors and eigenspace direct sum do not. This is a change of coefficient ring for the algebra and modules; the real Gaussian law is not being extended to characteristic two.
TauCeti's
MonoidAlgebra.isIdempotentElem_cyclicTwo_iff
proves the idempotent obstruction more generally for a commutative
nonzero ring without zero divisors in which \(2\) is not a unit. A
characteristic-two field meets these hypotheses. The generator is
identified with \(\operatorname {Multiplicative.ofAdd}
(1:\mathbb Z/2\mathbb Z)\) as in Theorem [fdip-003O].
Indeed, if \(a+bg\) is idempotent, coefficient comparison gives
\(a^2+b^2=a\) and \(2ab=b\). Hence \(b(2a-1)=0\).
If \(b\ne 0\), absence of zero divisors gives \(2a=1\), contradicting
the nonunit hypothesis. Therefore \(b=0\) and \(a\in \{0,1\}\).
This argument does not require characteristic two, but does require
absence of zero divisors. The dual-number presentation and the
coordinate nilpotent above are separate characteristic-two calculations.
Finite-group symmetry of Gaussian fields [fdip-004R]AGENTDRAFTED
- October 31, 2026
Finite-group symmetry of Gaussian fields [fdip-004R]AGENTDRAFTED
- October 31, 2026
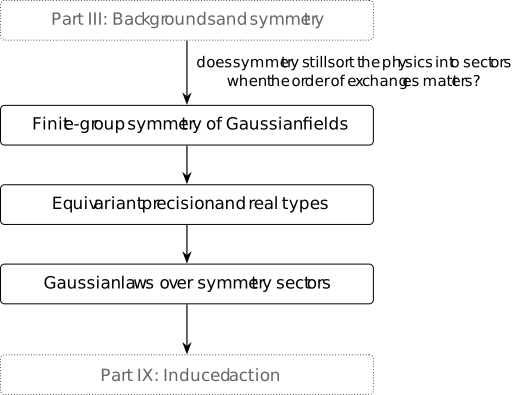
The half-turn splits fields into two sectors that its commuting precision does not mix. Does symmetry still separate the field when the order of exchanges matters? On the uniform cycle, each complex scalar Fourier wave spans a one-dimensional sector labelled by a discrete momentum. Real fields pair the nonexceptional momenta \(k\) and \(-k\) in a two-dimensional sector. For a general finite group, an isotypic sector collects all copies of one irreducible real representation: precision preserves that whole sector but can mix repeated copies within it. Orthogonal projectors recover these sectors from complex characters paired under conjugation. The prerequisites are signed endpoint actions, massive graph precision and the group-algebra extension.
Signed symmetries preserve the quadratic energy even when an edge is reversed. Maschke averaging and the complex central-idempotent formula supply the representation theory; the real projector theorem then gives a complete orthogonal decomposition preserved by precision. The cyclic and dihedral calculations show the resulting subspaces and eigenvalues explicitly.
Definition. Finite symmetries of a Gaussian background [fdip-004S]AGENTDRAFTED
- October 31, 2026
Definition. Finite symmetries of a Gaussian background [fdip-004S]AGENTDRAFTED
- October 31, 2026
Fix finite incidence data \((V,E,s,h)\), weights \(w_e>0\), a constant mass \(m>0\), and counting pairings on \(H=\mathbb R^V\) and \(\mathbb R^E\). A finite symmetry of a Gaussian background is a finite group \(G\) with a weight-preserving signed endpoint action \(g\mapsto (p_g,q_g,\varepsilon _g)\) on these data. No retained subset is selected here: in the signed-arrow definition one may take \(R=V\). An additional retained subset would have to be \(G\)-stable. The signs belong to the abstract \(C_2\) of that definition, with \(\sigma (+)=1\) and \(\sigma (-)=-1\). This unpartitioned data does not assert preservation of a nonempty proper retained set as in Definition [fdip-000G].
The vertex and edge representations are \[\begin {aligned} (\rho (g)f)(p_g(v))&=f(v),\\ (J_ga)(q_g(e))&=\sigma (\varepsilon _g(e))a(e). \end {aligned}\] Thus \(\rho (g)f=f\circ p_g^{-1}\); in particular \(\rho (g)\delta _v=\delta _{p_g(v)}\). We call \(H\) with this action the vertex permutation module. With \((df)(e)=f(h(e))-f(s(e))\), the endpoint equations give \(d\rho (g)=J_gd\). The sign cocycle gives \(\rho (gk)=\rho (g)\rho (k)\) and \(J_{gk}=J_gJ_k\). These conventions are the real specialization of Definition [fdip-003B], whose proof includes loops and parallel edge labels.
Write \(W=\operatorname {diag}(w_e)\) and \(Q=d^*Wd+m^2I\) for the massive precision. A reflection may reverse the chosen edge orientations; it is then a signed symmetry, not necessarily a directed relabeling in Definition [fdip-000G]. Forgetting those orientations preserves the energy, while still retaining incidence, weights and distinct edge labels. The underlying permutation-representation convention is [milne2025group, Example 7.1(b), p. 101]; the signed extension and its endpoint requirements are proved in Definition [fdip-003B].
Lemma. Signed symmetries commute with massive precision [fdip-004T]AGENTDRAFTED
- October 31, 2026
Lemma. Signed symmetries commute with massive precision [fdip-004T]AGENTDRAFTED
- October 31, 2026
For a finite symmetry of a Gaussian background, \(\rho (g)\) and \(J_g\) are orthogonal, \(J_gW=WJ_g\), and \[\rho (g)^*Q\rho (g)=Q,\qquad Q\rho (g)=\rho (g)Q.\] The Green operator \(Q^{-1}\) also commutes with every \(\rho (g)\).
Proof.
- October 31, 2026
Proof.
- October 31, 2026
Reindexing the counting sums gives \[\begin {aligned} \langle \rho (g)f,\rho (g)u\rangle _V&=\langle f,u\rangle _V,\\ \langle J_ga,J_gb\rangle _E&=\langle a,b\rangle _E. \end {aligned}\] The edge signs have square one. Since \(w_{q_g(e)}=w_e\), evaluation at \(q_g(e)\) proves \(WJ_g=J_gW\), and hence \(J_g^*WJ_g=W\). Using the incidence intertwiner, \[\begin {aligned} \rho (g)^*Q\rho (g) &=(d\rho (g))^*W(d\rho (g))+m^2I\\ &=d^*J_g^*WJ_gd+m^2I=Q. \end {aligned}\] Multiply on the left by \(\rho (g)\) to obtain commutation. Multiplication by \(Q^{-1}\) on both sides then proves the inverse claim. Equivalently, each reversed difference changes sign in \(\sum _e w_e(f(h(e))-f(s(e)))^2\) and leaves its square unchanged.
This specializes signed operator transport to positive real data. The incidence convention is [spielman2009effective, Section 2.1, pp. 4-5]; the argument above also covers loops and parallel labels.
Remark. From the half-turn to a finite group [fdip-004U]AGENTDRAFTED
- October 31, 2026
Remark. From the half-turn to a finite group [fdip-004U]AGENTDRAFTED
- October 31, 2026
For the four-cycle half-turn, \(G=C_2=\{1,r\}\) and \(\rho (r)=P\). Its two projectors are \((I+P)/2\) and \((I-P)/2\), with the concrete two-dimensional ranges. A larger symmetry group can split these ranges further; a sector for one chosen group is not an intrinsic label independent of that choice.
The group-algebra extension gives \[\widehat \rho :\mathbb R[G]\longrightarrow \operatorname {End}_{\mathbb R}(H), \qquad \widehat \rho \left (\sum _g a_g[g]\right )=\sum _g a_g\rho (g).\] It uses the group algebra and representation/module correspondence. Since every \(\rho (g)\) commutes with \(Q\), so does every \(\widehat \rho (a)\). The action groupoid organizes transported backgrounds, whereas this representation describes a fixed background's symmetry. The character-projector construction in [serre1977linear, Section 2.6, Theorem 8, pp. 21-22] recovers exactly the two half-turn projectors.
Theorem. Maschke averaging [fgap-001K]
L∃∀NAGENTDRAFTED
Theorem. Maschke averaging [fgap-001K]
L∃∀NAGENTDRAFTED
Let \(G\) be finite and \(k\) a field in which \(|G|\) is invertible. Every subrepresentation \(W\subseteq V\) has a \(G\)-stable complement. Consequently every finite-dimensional \(k[G]\)-module, and \(k[G]\) itself, is semisimple.
Proof.
Proof.
Choose a \(k\)-linear projection \(P:V\to W\) and average its conjugates: \[ P_G=\frac 1{|G|}\sum _{g\in G}\rho (g)P\rho (g)^{-1}. \] Then \(P_G\) remains the identity on \(W\) and commutes with \(G\). Its kernel is a \(G\)-stable complement. Division by \(|G|\) requires the stated invertibility hypothesis. This is Maschke's theorem as proved in [sengupta2010representations, thm. 3.5.1, pp. 44-46].
Theorem. primitive central idempotents as block projectors [fgap-001N]
Theorem. primitive central idempotents as block projectors [fgap-001N]
Over a splitting field of characteristic not dividing \(|G|\), an irreducible character \(\chi \) defines the central element \[ e_\chi =\frac {\chi (1)}{|G|}\sum _{g\in G}\chi (g^{-1})[g]. \] It is a nonzero primitive central idempotent. On a simple module with character \(\psi \), it acts as the identity if \(\psi =\chi \) and as zero otherwise. Distinct \(e_\chi \) are therefore orthogonal block projectors. See [lux2010representations, thm. 2.1.6 and cor. 2.1.7, pp. 88-90]. A constructed family of such projectors does not yield a complete block decomposition until a sum-to-1 statement is also known.
Theorem. Complete orthogonal real isotypic projectors [fdip-004V]AGENTDRAFTED
- October 31, 2026
Theorem. Complete orthogonal real isotypic projectors [fdip-004V]AGENTDRAFTED
- October 31, 2026
Let \(G\) be finite and let \(\rho \) be an orthogonal action on a finite-dimensional real inner-product space \(H\). Let \(Q\) be a linear operator commuting with every \(\rho (g)\). Write \(\operatorname {Irr}_{\mathbb C}(G)\) for the irreducible complex characters. For each orbit \(\Xi \) under \(\chi \mapsto \overline \chi \), put \[\begin {aligned} e_\chi &=\frac {\chi (1)}{|G|}\sum _{g\in G}\chi (g^{-1})[g],\\ \epsilon _\Xi &=\sum _{\chi \in \Xi }e_\chi , & P_\Xi &=\widehat \rho (\epsilon _\Xi ). \end {aligned}\] Then \(\epsilon _\Xi \) belongs to \(\mathbb R[G]\), is central, and is fixed by the real involution \([g]^*=[g^{-1}]\). The operators satisfy \[\begin {aligned} P_\Xi ^2&=P_\Xi =P_\Xi ^*,& QP_\Xi &=P_\Xi Q,\\ P_\Xi P_\Upsilon &=0\quad (\Xi \ne \Upsilon ),& \sum _\Xi P_\Xi &=I_H. \end {aligned}\] Thus \(H\) is the orthogonal direct sum of their ranges; a range may be zero. These ranges are its real isotypic sectors: each is the sum of all irreducible real subrepresentations of one isomorphism type. Complexification of a sector is the sum of the complex isotypic components with characters in \(\Xi \).
Proof.
- October 31, 2026
Proof.
- October 31, 2026
Maschke's theorem and the complex central-idempotent formula give central, pairwise orthogonal idempotents \(e_\chi \) acting on the indicated complex components. Coefficient conjugation sends \(e_\chi \) to \(e_{\overline \chi }\), so it fixes \(\epsilon _\Xi \); its coefficients are real. Average a Hermitian inner product on a complex representation over \(G\). Each group operator becomes unitary, whence \(\chi (g^{-1})=\overline {\chi (g)}\). The complex linear extension of \([g]\mapsto [g^{-1}]\) therefore sends \(e_\chi \) to \(e_{\overline \chi }\), and fixes \(\epsilon _\Xi \). This is coefficient conjugation and inversion separately; the latter restricts to the stated real involution.
For completeness, the regular character is \(r_G(g)=|G|\,\delta _{g,1}\) and decomposes as \(r_G=\sum _\chi \chi (1)\chi \) by [serre1977linear, Section 2.4, Proposition 5 and Corollary 1, p. 18]. Consequently \[\begin {aligned} \sum _\chi e_\chi &=\frac 1{|G|}\sum _{g\in G} \left (\sum _\chi \chi (1)\chi (g^{-1})\right )[g]\\ &=\frac 1{|G|}\sum _{g\in G}r_G(g^{-1})[g]=[1]. \end {aligned}\] Grouping by conjugation orbits preserves this sum. Applying \(\widehat \rho \) gives idempotence, mixed-product zero and sum \(I_H\). Orthogonality gives \(\rho (g)^*=\rho (g^{-1})\), so \(\widehat \rho (a^*)=\widehat \rho (a)^*\) for real coefficients. Thus each \(P_\Xi \) is self-adjoint; distinct ranges are perpendicular because \(\langle P_\Xi x,P_\Upsilon y\rangle =\langle x,P_\Xi P_\Upsilon y\rangle =0\). The sum identity gives existence of the decomposition, and applying each projector gives its uniqueness. Commutation with \(Q\) follows by linearity from commutation with every group operator.
To justify the real isotypic terminology, decompose \(H\) into irreducible real subrepresentations by Maschke. On any such \(U\), the real commuting idempotents \(P_\Xi \) have invariant ranges, so exactly one acts as the identity and the rest as zero. Its complexification therefore has constituents in just that orbit. Two real irreducibles assigned to the same orbit share a complex constituent: complex conjugation on each complexification exchanges the constituents indexed by \(\chi \) and \(\overline \chi \). Semisimplicity over \(\mathbb C\) then gives a nonzero complex intertwiner between their complexifications. In real bases, the real and imaginary parts of its matrix are real intertwiners, at least one nonzero. Its kernel and image are invariant, so irreducibility makes it an isomorphism. Conversely an isomorphism commutes with all the character projectors. This proves precisely the asserted grouping.
Serre's [serre1977linear, Section 2.6, Theorem 8, p. 21]
gives the canonical complex components and their projectors; the
real grouping and adjoint argument above are deductions from it.
TauCeti's
TauCeti.Representation.sum_primitiveCentralIdempotent
proves the complex sum-to-one identity for a finite pairwise inequivalent
family of irreducibles whose cardinality equals the number of conjugacy
classes, over an algebraically closed field with invertible group order.
It supports the completeness step, not the real adjoint or graph claims.
Example. Real Fourier sectors of a cycle [fdip-004W]AGENTDRAFTED
- October 31, 2026
Example. Real Fourier sectors of a cycle [fdip-004W]AGENTDRAFTED
- October 31, 2026
Let \(n\ge 3\), \(V=E=\mathbb Z/n\mathbb Z\), with edge \(e_v\) from \(v\) to \(v+1\), uniform weight \(w>0\) and mass \(m>0\). The generator \(r\) of \(C_n\) sends \(v\) to \(v+1\) and \(e_v\) to \(e_{v+1}\), with every edge sign positive. Its action on fields is \((\rho (r)f)(v)=f(v-1)\). The cyclic characters in [serre1977linear, Section 5.1, p. 35] and the real projectors yield the following direct calculation.
Set \(\theta _k=2\pi k/n\). The normalized constant vector \(u_0(v)=1/\sqrt n\) spans the trivial sector. For \(1\le k<n/2\), the sector \(H_k\) has orthonormal basis \[c_k(v)=\sqrt {2/n}\cos (\theta _kv),\qquad s_k(v)=\sqrt {2/n}\sin (\theta _kv).\] When \(n\) is even there is also \(u_{n/2}(v)=(-1)^v/\sqrt n\). These give all sectors indexed by \(0\le k\le \lfloor n/2\rfloor \). In the ordered basis \((c_k,s_k)\), the rotation is \[\rho (r)|_{H_k}=\begin {pmatrix} \cos \theta _k&-\sin \theta _k\\ \sin \theta _k&\cos \theta _k \end {pmatrix}.\] For \(0<\theta _k<\pi \) it has no real eigenline, so \(H_k\) is real irreducible. Its complex constituents have characters \(r\mapsto e^{i\theta _k}\) and \(r\mapsto e^{-i\theta _k}\).
Proof.
- October 31, 2026
Proof.
- October 31, 2026
The finite geometric sum \(\sum _{v=0}^{n-1}e^{2\pi i jv/n}\) equals \(n\) when \(n\) divides \(j\) and zero otherwise. Taking real and imaginary parts proves all stated norms and orthogonality. There are \(n\) basis vectors, so they span \(H\). The addition formulas give the displayed rotation. A real rotation through \(0<\theta _k<\pi \) has eigenvalues \(e^{\pm i\theta _k}\), neither real, proving the irreducibility claim.
The precision and each sector eigenvalue are \[\begin {aligned} (Qf)(v)&=(m^2+2w)f(v)-wf(v-1)-wf(v+1),\\ Q|_{H_k}&=q_kI,\\ q_k&=m^2+2w(1-\cos \theta _k). \end {aligned}\] Substitution of each sine, cosine and exceptional one-dimensional mode proves the formula. The orthogonal projector kernels are \[\begin {aligned} P_0(v,u)&=1/n,\\ P_k(v,u)&=\frac 2n\cos (\theta _k(v-u))\quad (0<k<n/2),\\ P_{n/2}(v,u)&=(-1)^{v-u}/n\quad (n\text { even}). \end {aligned}\] They follow by summing the outer products of the displayed orthonormal basis vectors, so their sum is the identity. For \(n=3\), this reads \(P_0=\mathbf 1\mathbf 1^T/3\) and \(P_1=I-P_0\); the eigenvalues are \(m^2\) and \(m^2+3w\), the latter twice. The later circle comparison rescales these same finite modes; no continuum limit is used in this calculation.
Example. Dihedral symmetry refines the four-cycle sectors [fdip-004X]AGENTDRAFTED
- October 31, 2026
Example. Dihedral symmetry refines the four-cycle sectors [fdip-004X]AGENTDRAFTED
- October 31, 2026
Take the cycle with \(n=4\), \(w=m=1\). Let \(D_4=\langle r,s:r^4=s^2=1,\ srs=r^{-1}\rangle \), of order 8, act on vertices by \(r(v)=v+1\), \(s(v)=-v\). On the oriented edges \(e_v:v\to v+1\), rotation sends \(e_v\) to \(e_{v+1}\) with positive sign, while reflection sends \(e_v\) to \(e_{-v-1}\) with negative sign. The latter edge runs from \(-v-1\) to \(-v\), the reverse of the transported endpoints. The 4 rotations restore each edge; two reflections restore its label and give positive sign. Reflecting, rotating, then reflecting sends \(e_v\) to \(e_{v-1}\) with two negative signs, hence agrees with the inverse rotation. The vertex maps obey the same relations, so these maps define a signed endpoint action. This uses the dihedral presentation in [serre1977linear, Section 5.3, p. 36]; the edge signs and precision calculation are explicit here.
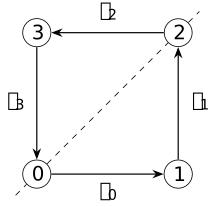
The dashed diagonal is the reflection axis: \(s\) fixes vertices \(0,2\), exchanges \(1,3\), and sends \(e_0\) to \(e_3\) with reversed orientation. All 4 weights and the mass are one.
An orthonormal basis, grouped by real irreducible type, is \[\begin {aligned} u&=(1,1,1,1)/2,&a&=(1,-1,1,-1)/2,\\ c&=(1,0,-1,0)/\sqrt 2,&b&=(0,1,0,-1)/\sqrt 2. \end {aligned}\] The line \(\mathbb Ru\) is trivial. On \(\mathbb Ra\), rotation acts by \(-1\) and reflection by \(+1\); call this the alternating line. On \(K=\operatorname {span}(c,b)\), \[\rho (r)|_K=\begin {pmatrix}0&-1\\1&0\end {pmatrix},\qquad \rho (s)|_K=\begin {pmatrix}1&0\\0&-1\end {pmatrix}.\] There is no real rotation-invariant line, so \(K\) is irreducible. A real matrix commuting with the rotation is \(xI+y\rho (r)\); commuting also with the reflection forces \(y=0\). Thus its commuting algebra is \(\mathbb R I\), the real-type case. The two distinct lines and \(K\) are pairwise nonisomorphic, each occurring once.
Direct substitution in the cycle precision gives \[Qu=u,\qquad Qa=5a,\qquad Qc=3c,\qquad Qb=3b.\] The three orthogonal projectors are \(uu^T\), \(aa^T\), and \(cc^T+bb^T=I-uu^T-aa^T\); their ranges have dimensions \(1,1,2\) and precision eigenvalues \(1,5,3\), respectively. For the subgroup generated by \(r^2\), the positive sector is \(\operatorname {span}(u,a)\) and the negative sector is \(K\). The half-turn calculation therefore has two \(2\times 2\) blocks, whereas the full dihedral action separates its positive block into two lines. Changing the acting group changes the isotypic decomposition without changing this precision.
Equivariant precision and real types [fdip-004Y]AGENTDRAFTED
- November 1, 2026
Equivariant precision and real types [fdip-004Y]AGENTDRAFTED
- November 1, 2026
A symmetry sector need not have a single precision eigenvalue. Several copies of the same irreducible representation can mix, as the half-turn commutant already shows. The real isotypic projectors separate inequivalent types; within each sector a matrix over the reals, complexes or quaternions records the remaining freedom.
The commutant and positive cone determine the size of these matrices. The Frobenius-Schur indicator then identifies their scalar algebra, with an explicit passage from complex invariant forms to real modules. A twisted prism exhibits a complex multiplicity matrix, and the binary tetrahedral Cayley graph exhibits all three scalar types. Throughout, a Laplacian block becomes a positive precision block only after the specified mass shift.
Theorem. The real commutant and multiplicity matrices [fdip-004Z]AGENTDRAFTED
- November 1, 2026
Theorem. The real commutant and multiplicity matrices [fdip-004Z]AGENTDRAFTED
- November 1, 2026
Let a finite group \(G\) act orthogonally on a finite-dimensional real space \(H\). In its isotypic decomposition, write \(H_\Xi \cong W_\Xi ^{\oplus m_\Xi }\), where \(W_\Xi \) is irreducible and \(m_\Xi >0\) is its multiplicity. The commutant consists of all linear maps commuting with \(G\). With multiplication given by composition, put \(D_\Xi =\operatorname {End}_G(W_\Xi )\). Then \[\begin {aligned} D_\Xi &\cong \mathbb R,\ \mathbb C\ \text {or}\ \mathbb H,\\ \operatorname {End}_G(H)&\cong \prod _\Xi M_{m_\Xi }(D_\Xi ). \end {aligned}\] The isomorphism can be chosen to carry adjunction to conjugate transpose. If \(H=\mathbb R^V\) is a vertex permutation representation, the real dimension of \(\operatorname {End}_G(H)\) is the number of orbits of the diagonal action \(g(u,v)=(gu,gv)\) on \(V\times V\). These orbits are called orbitals.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Maschke's theorem decomposes \(H\) orthogonally into irreducibles. The kernel and image of an intertwiner are invariant. Hence an intertwiner between inequivalent irreducibles is zero, and every nonzero endomorphism of one irreducible is invertible. Thus \(D_\Xi \) is a finite-dimensional associative real division algebra; Frobenius's division-algebra theorem gives the three displayed possibilities. Between \(m_\Xi \) identified copies the intertwiners are precisely matrices of elements of \(D_\Xi \), acting by \((Aw)_i=\sum _j A_{ij}(w_j)\). This proves the algebra statement. The real classification and its representation-theoretic use are [serre1977linear, Section 13.2, pp. 106-109]; compare the real-type distinction.
Adjunction preserves \(D_\Xi \). A self-adjoint element of it has real eigenspaces invariant under \(G\), so irreducibility makes it a real scalar. In particular \(d^*d=cI\) with \(c>0\) for \(d\ne 0\). The resulting positive adjoint on \(\mathbb R\), \(\mathbb C\) or \(\mathbb H\) is the usual conjugation: for an imaginary unit \(j^2=-1\), write \(j+j^*=2aI\) with \(a\in \mathbb R\). Then \(j^*j=2aj+I\) is scalar, forcing \(a=0\). Thus \(j^*=-j\). Identifications between equivalent orthogonal copies can be made isometric by dividing an intertwiner by the positive square root of its scalar \(T^*T\). In those coordinates the block adjoint is conjugate transpose.
For vertex permutations, a matrix \(A\) commutes with every \(\rho (g)\) exactly when \(A_{gu,gv}=A_{u,v}\). Its entries are therefore constant on orbitals. The indicator matrices of distinct orbitals have disjoint supports and form a real basis of the commutant, proving the dimension formula.
The scalar-side convention matters for \(\mathbb H\). Here \(D_\Xi \) acts on \(W_\Xi \) on the left by endomorphisms. If instead \(W_\Xi \) is presented as a left module for a simple matrix algebra, its commuting scalars act on the right and form an opposite algebra, as in Proposition [fcap-0042]. Quaternion conjugation identifies that opposite algebra with \(\mathbb H\); it does not license reversing the order of quaternion products.
Corollary. Positive multiplicity blocks and real dimensions [fdip-0050]AGENTDRAFTED
- November 1, 2026
Corollary. Positive multiplicity blocks and real dimensions [fdip-0050]AGENTDRAFTED
- November 1, 2026
Under the commutant identification, an equivariant self-adjoint positive definite precision \(Q\) is specified by \(Q_\Xi \in M_{m_\Xi }(D_\Xi )\) with \(Q_\Xi ^*=Q_\Xi >0\). Thus all such precisions form an open cone in a real vector space of dimension \[\sum _\Xi h(m_\Xi ,D_\Xi ),\qquad \begin {array}{c|ccc} D&\mathbb R&\mathbb C&\mathbb H\\\hline h(m,D)&m(m+1)/2&m^2&2m^2-m. \end {array}\] For a vertex permutation representation this dimension also counts \(G\)-orbits on unordered pairs \(\{u,v\}\), including \(u=v\). This is the full cone of equivariant precisions; graph Laplacians with prescribed edges and positive weights generally form a smaller family.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Choose an orthonormal basis of \(W_\Xi \) as a left \(D_\Xi \)-space, using the positive adjoint of Theorem [fdip-004Z]. Explicitly, an orthonormal real set \(e,ie\) or \(e,ie,je,ke\) spans one such scalar line; its real orthogonal complement is \(D_\Xi \)-stable, so induction constructs the basis. Put \(r_\Xi =\dim _{D_\Xi }W_\Xi \) and \(d_D=\dim _{\mathbb R}D\in \{1,2,4\}\). Expanding each of the \(m_\Xi \) vectors in this basis identifies \(H_\Xi \) with \(r_\Xi \) columns in \(D_\Xi ^{m_\Xi }\). The same matrix \(Q_\Xi \) acts on every column by left multiplication. The real inner product is the sum of \(\operatorname {Re}(z^*w)\) on these columns. Consequently positivity of \(Q|_{H_\Xi }\) is exactly positivity of \(Q_\Xi \).
A Hermitian matrix has \(m\) real diagonal entries and \(m(m-1)/2\) freely chosen off-diagonal entries in \(D\); the opposite entries are their conjugates. This gives \(h(m,D)=m+d_Dm(m-1)/2\). Positive definiteness is open because \(\langle Qx,x\rangle \) has a strictly positive minimum on the unit sphere. In permutation coordinates a symmetric commuting matrix is constant on unordered-pair orbits, whose indicator matrices again form a basis.
These coordinates fix the determinant convention without a noncommutative determinant ambiguity: \[\begin {aligned} \dim _{\mathbb R}H_\Xi &=m_\Xi r_\Xi d_{D_\Xi },\\ \det _{\mathbb R}(Q|_{H_\Xi }) &=\det _{\mathbb R}(Q_\Xi :D_\Xi ^{m_\Xi }\to D_\Xi ^{m_\Xi })^{r_\Xi }. \end {aligned}\] For a positive Hermitian block with eigenvalues \(\lambda _1,\ldots ,\lambda _m\), the latter real determinant is \(\prod _j\lambda _j^{d_D}\). The spectral assertion follows by taking an eigenvector of the real self-adjoint operator: its eigenspace is stable under right scalar multiplication on \(D^m\); its scalar line has an invariant orthogonal complement, and induction gives a \(D\)-orthonormal eigenbasis. In particular a complex determinant is squared, and the product of quaternionic Hermitian eigenvalues is raised to the fourth power, before taking the exponent \(r_\Xi \). This is the positive-matrix specialization of the real block classification in [serre1977linear, Section 13.2, pp. 108-109].
For a graph write \(L=d^*Wd\) and \(Q=L+m^2I\), with \(m^2>0\). The multiplicity matrices obey \(Q_\Xi =L_\Xi +m^2I\). A zero Laplacian eigenvalue therefore gives a strictly positive precision eigenvalue \(m^2\), not a normalized massless Gaussian.
Theorem. the Frobenius-Schur trichotomy [fgap-0021]
Theorem. the Frobenius-Schur trichotomy [fgap-0021]
Let \(\rho \) be an irreducible finite-dimensional representation of a finite group over an algebraically closed field of characteristic 0. Its Frobenius-Schur indicator \[ \nu _2(\rho )=\frac 1{|G|}\sum _{g\in G}\chi _\rho (g^2) \] takes exactly 1 of the values \(1\), \(0\), and \(-1\). The value \(1\) is equivalent to the existence of a nondegenerate invariant symmetric bilinear form; \(-1\) is equivalent to a nondegenerate invariant alternating form; and \(0\) is equivalent to the absence of a nonzero invariant bilinear form. See [james2001representations, def. 23.13, the proof of thm. 23.14, and thm. 23.16, pp. 273-277]. James and Liebeck state the alternatives using nonzero invariant forms; for an irreducible representation, a nonzero invariant symmetric or alternating form has zero radical and is therefore nondegenerate.
This trichotomy classifies the invariant-form behavior of the complex irreducible representation. It does not by itself compute a Schur index or a complete decomposition after descent to \(\mathbb R\).
Proposition. From Frobenius-Schur indicators to real Gaussian types [fdip-0051]AGENTDRAFTED
- November 1, 2026
Proposition. From Frobenius-Schur indicators to real Gaussian types [fdip-0051]AGENTDRAFTED
- November 1, 2026
Let \(W\) be an irreducible real representation of a finite group, \(D=\operatorname {End}_G(W)\), and \(\chi \) an irreducible constituent of \(W_{\mathbb C}=W\otimes _{\mathbb R}\mathbb C\). The Frobenius-Schur indicator gives exactly the following possibilities, where \(X_\chi \) denotes a complex module of character \(\chi \): \[\begin {array}{c|c|c|c} \nu _2(\chi )&D&W_{\mathbb C}&\dim _{\mathbb R}W\\\hline 1&\mathbb R&X_\chi &\chi (1)\\ 0&\mathbb C&X_\chi \oplus X_{\bar \chi }&2\chi (1)\\ -1&\mathbb H&X_\chi \oplus X_\chi &2\chi (1). \end {array}\] In the middle row \(\chi \ne \bar \chi \). In the last row \(\chi (1)\) is even and \(\dim _{\mathbb H}W=\chi (1)/2\). The form trichotomy alone is not the real descent argument; these assertions use the bridge proved below. They agree with [serre1977linear, Section 13.2, Proposition 39, p. 109].
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Commutation with the finitely many real group matrices is a system of real linear equations. Complexifying its solution space therefore gives \[\operatorname {End}_G(W_{\mathbb C}) \cong D\otimes _{\mathbb R}\mathbb C.\] For \(D=\mathbb R,\mathbb C,\mathbb H\) the right side is respectively \(\mathbb C\), \(\mathbb C\times \mathbb C\), \(M_2(\mathbb C)\). For the middle identity use \(z\otimes a\mapsto (za,\bar z a)\); for the last use the usual quaternion two-by-two complex matrices, whose complex span is all \(M_2(\mathbb C)\), as in Proposition [fcap-0042]. Complex semisimplicity identifies the left side with \(\prod _\psi M_{n_\psi }(\mathbb C)\), where \(n_\psi \) is the constituent multiplicity. Its simple factors and their dimensions force one constituent once, two distinct constituents once each, or one constituent twice, respectively.
Let \(c(w+iv)=w-iv\). It exchanges the \(\psi \) and \(\bar \psi \) components. If \(D=\mathbb R\), the single complex irreducible has the real form \(W\). Averaging a real inner product and complexifying it supplies an invariant nondegenerate symmetric bilinear form, so \(\nu _2=1\). If \(D=\mathbb C\) and either of the two inequivalent components were fixed by \(c\), its fixed vectors would be a nonzero proper real invariant subspace of \(W\). Indeed, for a \(c\)-stable space every vector is uniquely \((x+cx)/2+i(x-cx)/(2i)\) with both components fixed by \(c\). Irreducibility excludes this, so the two characters are a nonreal conjugate pair and \(\nu _2=0\).
If \(D=\mathbb H\), conjugation fixes the sole constituent type, so \(\chi =\bar \chi \) and \(\nu _2=\pm 1\). Suppose \(\nu _2=1\). Choose a nondegenerate invariant symmetric complex bilinear form \(B\) on \(X_\chi \) and an averaged invariant positive Hermitian form \(h\), conjugate-linear in its first argument. There is a unique antilinear map \(J\) with \(B(x,y)=h(Jx,y)\), and it commutes with \(G\). In an \(h\)-orthonormal basis write \(B(x,y)=x^TAy\). Then \(A^T=A\), \(Jx=\bar A\bar x\) and \(J^2=\bar A A=A^*A>0\). By complex Schur's lemma \(J^2=tI\) for a positive real \(t\). Replacing \(J\) by \(t^{-1/2}J\) makes \(J^2=I\). Its fixed space \(U\) is a real form of \(X_\chi \), by the same two-component formula. This is the irreducible specialization of [serre1977linear, Section 13.2, Theorem 31, pp. 106-108].
The real module \(U\) is irreducible, since a proper real invariant subspace would complexify to a proper subspace of \(X_\chi \). There is a nonzero complex intertwiner \(U_{\mathbb C}\to W_{\mathbb C}=X_\chi ^{\oplus 2}\). In real bases its real or imaginary part gives a nonzero real intertwiner \(U\to W\), which must be an isomorphism by irreducibility. But \(\dim _{\mathbb R}U=\chi (1)\) and \(\dim _{\mathbb R}W=2\chi (1)\), a contradiction. Thus \(\nu _2=-1\). The three division algebras exhaust the cases and give distinct indicators, so all implications reverse. Finally \(W\) is a left \(\mathbb H\)-space, making its real dimension a multiple of 4; hence \(\chi (1)\) is even.
For an equivariant centered real Gaussian on an isotypic sector, use the coordinates \(z_1,\ldots ,z_r\in D^m\) of Corollary [fdip-0050]. Its real density is proportional to \[\exp \left (-\frac 12\sum _{a=1}^r \operatorname {Re}(z_a^*Q_\Xi z_a)\right ).\] The real covariance is the Hermitian multiplicity matrix \(Q_\Xi ^{-1}\) acting on each column. For \(D=\mathbb C\), multiplication of a column by \(e^{i\theta }\) preserves this real law: this is circular symmetry. With the displayed real normalization the complex second moment is \(\mathbb E[z_a z_a^*]=2Q_\Xi ^{-1}\). For \(D=\mathbb H\), right multiplication \(z_a\mapsto z_a q\) by a unit quaternion likewise preserves the real quadratic form and Lebesgue measure. This is the asserted quaternionic symmetry; left multiplication by an arbitrary quaternion need not commute with the entries of \(Q_\Xi \). These coordinate symmetries need not be additional graph symmetries. The real Gaussian normalization and covariance are those of Theorem [fdip-000H].
TauCeti's
Representation.frobeniusSchurIndicator_eq_one_iff_isRealizableOverReal
proves the indicator-one/real-realizability equivalence for an
irreducible complex representation of a finite group. It supports
the real-form step; the full commutant identification, all three
real dimensions and the Gaussian coordinate statements are the
arguments above.
Example. A twisted prism with a complex multiplicity block [fdip-0052]AGENTDRAFTED
- November 1, 2026
Example. A twisted prism with a complex multiplicity block [fdip-0052]AGENTDRAFTED
- November 1, 2026
Take two triangles with vertices \(x,x'\) indexed by \(x\in \mathbb Z/3\mathbb Z\). Give the upper triangle weight \(a=1\), the lower triangle weight \(b=2\), the edges \(\{x,x'\}\) weight \(u=1\), and the edges \(\{x,(x+1)'\}\) weight \(v=1/2\). The graph precision is \(Q=L+I\). Each edge is undirected for the energy; arbitrary chosen orientations are transported with the signed convention.
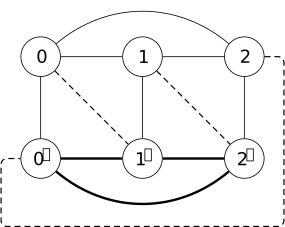
Thin solid edges have weight \(1\); the thick lower triangle has weight \(2\); dashed edges have weight \(1/2\). The outer dashed edge joins \(2\) to \(0'\), completing the shift modulo three. Crossings without a circle are not vertices.
The simultaneous rotation \(x\mapsto x+1\) generates \(C_3\). It is the entire weight-preserving vertex automorphism group. The weighted degrees \(7/2\) and \(11/2\) distinguish the two layers. The interlayer edges of weight \(1\) force the same permutation \(\pi \) on both layers, and those of weight \(1/2\) force \(\pi (x+1)=\pi (x)+1\). Thus only the three rotations remain.
The real representation is \(\mathbb R^6\cong \mathbb R^{\oplus 2}\oplus W^{\oplus 2}\), where \(W\) is the two-dimensional rotation representation and has \(D=\mathbb C\) by Proposition [fdip-0051]. The commutant is \(M_2(\mathbb R)\times M_2(\mathbb C)\), of real dimension \(4+8=12\). Its orbitals are the 4 choices of ordered layers and three differences \(y-x\). The symmetric dimension is \(3+4=7\): there are two diagonal orbits, two within-layer edge orbits and three interlayer pair orbits.
Use normalized constant vectors on the two layers for the trivial sector. For the other sector put \(\zeta =e^{2\pi i/3}\) and represent its upper values by \(f(x)=\sqrt {2/3}\operatorname {Re}(z\zeta ^{-x})\), and its lower values by the same formula with \(z'\). This is an isometry from \(\mathbb C^2\) with its real Euclidean inner product to the four-dimensional sector. Evaluating the edge energy gives \[\begin {aligned} Q_{\mathrm {triv}}&= \begin {pmatrix}5/2&-3/2\\-3/2&5/2\end {pmatrix},\\ Q_{\mathbb C}&= \begin {pmatrix} 11/2&-3/4+i\sqrt3/4\\ -3/4-i\sqrt3/4&17/2 \end {pmatrix}. \end {aligned}\] Indeed the diagonal Fourier entries are \(1+3a+u+v\) and \(1+3b+u+v\); the upper-right entry is \(-u-v\zeta ^{-1}\). The trivial eigenvalues are \(1,4\). The complex block has trace \(14\), determinant \(46\), and eigenvalues \(7-\sqrt 3,7+\sqrt 3\), each repeated twice over the reals. Hence \[\det _{\mathbb R}Q=4\cdot 46^2=8464.\] The square is required by the real determinant convention.
The imaginary entry records the shift in the declared Fourier coordinates. Rephasing one coordinate can make this single Hermitian matrix real; the intrinsic complex feature is the full commutant \(M_2(\mathbb C)\), not an obstruction to diagonalizing one positive operator. This calculation adapts the cyclic Fourier modes of Example [fdip-004W], based on [serre1977linear, Section 5.1, p. 35].
Example. All real types in a binary tetrahedral Cayley graph [fdip-0053]AGENTDRAFTED
- November 1, 2026
Example. All real types in a binary tetrahedral Cayley graph [fdip-0053]AGENTDRAFTED
- November 1, 2026
Let \(T=2T\) be the 24 Hurwitz units, with \(\omega =(-1+i+j+k)/2\), and take the inverse-closed generating set \[S=\{i,-i,j,-j,k,-k,\omega ,\bar \omega \}.\] Give each unordered edge \(\{g,gs\}\) weight one, counting it once. There are no loops, the degree is 8, and left multiplication acts by signed graph symmetries. On \(\mathbb R^T\) the Laplacian is \[(Lf)(g)=8f(g)-\sum _{s\in S}f(gs).\] The underlying group construction is [voight2021quaternion, Section 11.2, pp. 166-168]. The following spectrum and blocks are calculations for this particular generating set.
The quotient \(T/Q_8\cong C_3\) gives the character \(\lambda (\omega )=\zeta =e^{2\pi i/3}\), \(\lambda |_{Q_8}=1\). Let \(\sigma \) be the defining two-dimensional complex quaternion representation, with \(\chi _\sigma (q)=2\operatorname {Re}q\), and let \(\tau \) act by quaternion conjugation on \(\operatorname {span}_{\mathbb R}\{i,j,k\}\). Its character is \(4(\operatorname {Re}q)^2-1\). The 7 conjugacy classes and their characters are \[\begin {array}{c|rrrrrrr} q&1&-1&i&\omega &-\omega &\omega ^2&-\omega ^2\\\hline |[q]|&1&1&6&4&4&4&4\\ \lambda ^j&1&1&1&\zeta ^j&\zeta ^j&\zeta ^{2j}&\zeta ^{2j}\\ \sigma \lambda ^j&2&-2&0&-\zeta ^j&\zeta ^j&-\zeta ^{2j}&\zeta ^{2j}\\ \tau &3&3&-1&0&0&0&0 \end {array}\] with \(j=0,1,2\). The class of \(i\) comprises \(\{\pm i,\pm j,\pm k\}\); each remaining class is determined by its \(Q_8\)-coset and real part. These descriptions follow by conjugating the explicit Hurwitz units.
Using the displayed sizes, the character inner products are \(\delta _{\alpha \beta }\) and the sum of squared degrees is \(3\cdot 1^2+3\cdot 2^2+3^2=24\). Thus the 7 characters are irreducible, inequivalent and complete. Squaring sends the first three classes to \(1,1,-1\), the two \(\pm \omega \) classes to \([\omega ^2]\), and the two \(\pm \omega ^2\) classes to \([\omega ]\). Substitution into \(|T|^{-1}\sum _g\chi (g^2)\) gives indicators \(1,0,0\) for \(1,\lambda ,\lambda ^2\), \(-1,0,0\) for \(\sigma ,\sigma \lambda ,\sigma \lambda ^2\), and \(1\) for \(\tau \). For example the numerator for \(\sigma \) is \(2+2-12-16=-24\); for \(\sigma \lambda \) it is \(4-12-8(\zeta +\zeta ^2)=0\). The real-type bridge therefore gives \[\operatorname {End}_T(\mathbb R^T) \cong \mathbb R\times \mathbb C\times M_3(\mathbb R) \times \mathbb H\times M_2(\mathbb C).\] Here the regular real multiplicity is \(m_\Xi =\dim _{D_\Xi }W_\Xi \): a real simple matrix algebra \(M_r(D)\) has \(r\) column copies of its defining module, as in Proposition [fcap-0042].
Fourier decomposition of right translation gives, up to the chosen dual-basis convention, the block \(8I-\sum _{s\in S}\pi (s)\). Its adjoint or transpose gives the same spectra and determinants, since \(S=S^{-1}\). The multiplicity matrices are as follows; in the table \(m\) is multiplicity, not the mass parameter: \[\begin {array}{c|c|c|c|c} W\text { type}&D&m&\dim _{\mathbb R}W&L_\Xi \\\hline 1&\mathbb R&1&1&0\\ \lambda ,\bar \lambda &\mathbb C&1&2&3\\ \tau &\mathbb R&3&3&11I_3-J_3\\ \sigma &\mathbb H&1&4&9\\ \sigma \lambda ,\sigma \bar \lambda &\mathbb C&2&4&\operatorname {diag}(6,9) \end {array}\] Here \(J_3\) is the all-ones matrix. For \(\tau \), the 6 \(\pm i,\pm j,\pm k\) contribute \(-2I_3\), while \(\tau (\omega )+\tau (\bar \omega )=J_3-I_3\); the block has eigenvalues \(8,11,11\). For \(\sigma \) the 6 contributions cancel and \(\sigma (\omega )+\sigma (\bar \omega )=-I_2\), giving \(9\). For \(\sigma \lambda \), diagonalize \(\sigma (\omega )\) with eigenvalues \(\zeta ,\zeta ^2\). The twisted adjacency sum has eigenvalues \(-1,2\), giving \(9,6\). The nonreal linear pair has adjacency eigenvalue \(6+\zeta +\zeta ^2=5\).
The real sector dimensions are \(1,2,9,4,8\), summing to \(24\). Consequently \[\operatorname {spec}(L)=\{0,3^{[2]},6^{[4]},8^{[3]},9^{[8]},11^{[6]}\},\] where brackets denote eigenvalue multiplicity. For a mass squared \(a>0\), set \(Q=L+aI\); every block receives the same shift and \[\begin {aligned} \det _{\mathbb R}Q={}&a(a+3)^2(a+6)^4\\ &\cdot (a+8)^3(a+9)^8(a+11)^6. \end {aligned}\] The complex and quaternionic exponents are real dimensions, not complex degrees copied without descent. The commutant dimension is \(24\); the symmetric dimension is \(13\), also the number of inversion orbits in \(T\), since only \(1,-1\) are self-inverse. These are finite graph calculations; the possible physical interpretations discussed in Remark [fgap-0018] are separate hypotheses.
Gaussian laws over symmetry sectors [fdip-0054]AGENTDRAFTED
- November 1, 2026
Gaussian laws over symmetry sectors [fdip-0054]AGENTDRAFTED
- November 1, 2026
The real isotypic projectors split a field space, and the positive multiplicity matrices describe its symmetry-preserving precisions. For a real Gaussian field this becomes a product of independent sector laws, with real dimensions and normalizers fixed by the scalar type. The result extends the two-sector product law.
If the retained vertices form a union of group orbits, elimination can be performed separately in each sector. Symmetry survives, but the retained precision can change: keeping every other vertex of a cycle produces a new cycle with different weight and mass. Its exact periodic covariance explains the change of decay scale without identifying a finite ring with an infinite lattice.
Theorem. Independent Gaussian laws on real isotypic sectors [fdip-0055]AGENTDRAFTED
- November 1, 2026
Theorem. Independent Gaussian laws on real isotypic sectors [fdip-0055]AGENTDRAFTED
- November 1, 2026
Let a finite group \(G\) act orthogonally on a finite-dimensional real inner-product space \(H\), and let \(Q>0\) be self-adjoint and \(G\)-equivariant. Write the orthogonal isotypic projectors as \(E_\Xi \), put \(H_\Xi =E_\Xi H\), and omit the zero sectors. Use induced Euclidean volumes and uncompleted Borel sigma-algebras. For the normalized Gaussian law \(\mu _Q\), the map \[\mathcal D:H\longrightarrow \prod _\Xi H_\Xi , \qquad z\longmapsto (E_\Xi z)_\Xi \] satisfies \[\mathcal D_*\mu _Q=\bigotimes _\Xi \mu _{Q|_{H_\Xi }}. \qquad Z_Q=\prod _\Xi Z_{Q|_{H_\Xi }}.\] Thus the projected fields are independent. Each has covariance \((Q|_{H_\Xi })^{-1}\) on its own real sector.
In the multiplicity coordinates, set \(D_\Xi =\operatorname {End}_G(W_\Xi )\), \(r_\Xi =\dim _{D_\Xi }W_\Xi \), and \(d_\Xi =\dim _{\mathbb R}D_\Xi \in \{1,2,4\}\). Write \(Q_\Xi \in M_{m_\Xi }(D_\Xi )\) for the multiplicity matrix; it is not the entire real-sector matrix. Then \[\begin {aligned} \det _{\mathbb R}Q &=\prod _\Xi \det _{\mathbb R} (Q_\Xi :D_\Xi ^{m_\Xi }\to D_\Xi ^{m_\Xi })^{r_\Xi },\\ Z_{Q|_{H_\Xi }} &=\frac {(2\pi )^{m_\Xi r_\Xi d_\Xi/2}} {\det _{\mathbb R}(Q_\Xi )^{r_\Xi/2}}. \end {aligned}\] The determinants in these formulas are ordinary determinants of real linear operators, including when \(D_\Xi =\mathbb H\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The projectors are self-adjoint, mutually orthogonal and sum to \(I\). Addition from the product of their images is an isometry inverse to \(\mathcal D\). Concatenated orthonormal bases identify the orthogonal product volume with volume on \(H\); finite products of these Borel spaces have the product Borel sigma-algebra. Commutation with every projector makes \(Q\) block diagonal, so its positive quadratic form is the sum of its sector quadratic forms. The exponential weight therefore factors.
Each restricted precision is positive, and the Gaussian normalizer theorem makes every sector integral finite and positive. Nonnegative Tonelli gives the product of normalizers. Integrating the factored density on a Borel rectangle gives the product of its sector probabilities; uniqueness of finite measures on the rectangle-generated sigma-algebra gives the stated product law. This is the same measure argument as in Theorem [fdip-000M], now for the finite family of projectors. The inverse-precision covariance theorem applies to each factor. Empty sectors have unit normalizer and their one-point law.
For the determinant, the real-sector matrix is the direct sum of \(r_\Xi \) identical real operators \(Q_\Xi \) on \(D_\Xi ^{m_\Xi }\), by the orthonormal scalar-column construction of Corollary [fdip-0050]. Determinants multiply under real direct sums. If the positive Hermitian eigenvalues of \(Q_\Xi \) are \(\lambda _1,\ldots ,\lambda _{m_\Xi }\), its real determinant is \(\prod _j\lambda _j^{d_\Xi }\). Substitution into the real Gaussian normalizer gives the displayed formula.
For the twisted prism, the trivial multiplicity matrix has determinant \(4\), while the complex matrix has complex determinant \(46\). Both have \(r_\Xi =1\), so \(\det _{\mathbb R}Q=4\cdot 46^2=8464\) and \(Z_Q=(2\pi )^3/92\). For the binary tetrahedral Cayley graph, write \(a=m^2>0\). The 5 real sectors give the following factors: \[\begin {array}{c|c|c} D_\Xi &r_\Xi &\det _{\mathbb R}(Q|_{H_\Xi })\\\hline \mathbb R&1&a\\ \mathbb C&1&(a+3)^2\\ \mathbb R&3&[(a+8)(a+11)^2]^3\\ \mathbb H&1&(a+9)^4\\ \mathbb C&2&[(a+6)(a+9)]^4 \end {array}\] Their product is \[\det _{\mathbb R}Q =a(a+3)^2(a+6)^4(a+8)^3(a+9)^8(a+11)^6.\] The exponents sum to \(24\), the real field dimension. The normalizer is \[Z_Q=\frac {(2\pi )^{12}}{\sqrt {\det _{\mathbb R}Q}}.\] These factors use the mass-shifted precision, not the singular Laplacian alone.
The density convention agrees with [friedli2017statistical, Theorem 8.4, p. 385] after setting its mean to zero and its covariance to \(\Sigma =Q^{-1}\). That theorem identifies the Gaussian density; the finite-group projectors and real determinant exponents are supplied by the proofs above and in Corollary [fdip-0050].
Mathlib's
ProbabilityTheory.HasGaussianLaw.iIndepFun_of_covariance_inner
supports the independence step for a finite family of jointly
Gaussian real Hilbert-space variables. Here the family is
\(z\mapsto (E_\Xi z)_\Xi \), a linear image of the Gaussian field.
For distinct sectors and \(u\in H_\Xi \), \(v\in H_\Psi \), its
scalar cross covariance is \(\langle u,Q^{-1}v\rangle =0\),
because \(Q^{-1}\) preserves the orthogonal sectors. Thus the
declaration's zero-cross-covariance hypothesis matches this family.
It does not assert the representation-theoretic decomposition or the
real determinant exponents.
Theorem. Equivariant elimination within each sector [fdip-0056]AGENTDRAFTED
- November 1, 2026
Theorem. Equivariant elimination within each sector [fdip-0056]AGENTDRAFTED
- November 1, 2026
Let \(H=X\mathbin \perp Y\) be a finite-dimensional orthogonal real representation of a finite group \(G\), with both summands \(G\)-stable. Let the positive self-adjoint equivariant precision be \[Q=\begin {pmatrix}A&B\\B^*&C\end {pmatrix}, \qquad B:Y\to X.\] Then \(C>0\), and the retained precision \(S=A-BC^{-1}B^*:X\to X\) is positive, self-adjoint and \(G\)-equivariant. For every real irreducible type \(\Xi \), set \(X_\Xi =E_\Xi X\) and \(Y_\Xi =E_\Xi Y\). All block maps restrict to the indicated source and target sectors, and \[S|_{X_\Xi } =A|_{X_\Xi }-B_\Xi (C|_{Y_\Xi })^{-1}B_\Xi ^*.\] In common multiplicity coordinates, the same formula is \[S_\Xi =A_\Xi -B_\Xi C_\Xi ^{-1}B_\Xi ^*,\] where \(B_\Xi \) is an \(m_{X,\Xi }\times m_{Y,\Xi }\) matrix over \(D_\Xi \), and the products retain their displayed order.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Let \(\rho _X,\rho _Y\) denote the actions on the two summands. Equivariance of \(Q\) gives \(A\rho _X(g)=\rho _X(g)A\), \(B\rho _Y(g)=\rho _X(g)B\), and \(C\rho _Y(g)=\rho _Y(g)C\), together with the adjoint identity for \(B^*\). Positivity on \((0,y)\) makes \(C\) positive and invertible. Its inverse commutes with \(\rho _Y(g)\) by multiplying the commuting identity by \(C^{-1}\) on both sides. Hence the composite \(BC^{-1}B^*:X\to X\) and \(S\) commute with \(\rho _X(g)\). The same relations hold for the projectors, since they are real linear combinations of group actions.
Consequently \(B^*\) takes \(X_\Xi \) to \(Y_\Xi \), \(C^{-1}\) preserves \(Y_\Xi \), and \(B\) takes \(Y_\Xi \) back to \(X_\Xi \). The restriction of \(C^{-1}\) is the inverse of the restriction of \(C\), by restricting both inverse identities. This proves the typed formula, extending Proposition [fdip-003Q]. Choose isometric copies of the same real irreducible in \(X_\Xi \) and \(Y_\Xi \). Intertwiners then become rectangular matrices over \(D_\Xi \) and composition becomes ordered matrix multiplication, with adjunction given by conjugate transpose. This proves the multiplicity formula also over \(\mathbb H\); no scalar factors have been commuted. An absent \(Y_\Xi \) contributes a zero composite.
Completing the real square gives \[\begin {aligned} \langle (x,y),Q(x,y)\rangle &=\langle x,Sx\rangle \\ &\quad +\langle y+C^{-1}B^*x, C(y+C^{-1}B^*x)\rangle . \end {aligned}\] Testing at \(y=-C^{-1}B^*x\) proves \(S>0\); its self-adjointness follows by adjointing the composite. This uses the real inner product, regardless of the scalar algebra of a multiplicity matrix.
Use induced Euclidean volumes and let \(\pi :H\to X\) be the orthogonal projection. For every fixed \(x\), translation in \(Y\) and the completed square give \[\int _Y e^{-\langle (x,y),Q(x,y)\rangle/2}\,d\lambda _Y(y) =Z_Ce^{-\langle x,Sx\rangle/2}.\] Nonnegative Tonelli and normalization therefore give \(Z_Q=Z_CZ_S\) and \(\pi _*\mu _Q=\mu _S\), as in positive elimination. Applying the same argument in \(X_\Xi \mathbin \perp Y_\Xi \), and then the sector product law, gives \[\begin {aligned} (\mathcal D_X)_*\pi _*\mu _Q &=\bigotimes _\Xi \mu _{S|_{X_\Xi }},\\ (\pi _\Xi )_*\mu _{Q|_{H_\Xi }} &=\mu _{S|_{X_\Xi }},\qquad Z_C=\prod _\Xi Z_{C|_{Y_\Xi }}. \end {aligned}\] Here \(\pi _\Xi :H_\Xi \to X_\Xi \); the identity \(\pi E_\Xi =E_\Xi \pi \) shows that decomposing and projecting commute as maps. Product measures then give the same commuting square as in Theorem [fdip-003R], with all real isotypic sectors in place of the two sign sectors.
For vertex fields, the hypothesis holds when the retained set \(R\) is \(G\)-stable: take \(X=\mathbb R^R\) and \(Y=\mathbb R^{V\setminus R}\). It asserts equivariance of the induced marginal law. It does not assert that \(S=A\), the compressed precision. The cycle decimation gives a \(G\)-stable retained set with a nonzero Schur correction.
Example. Cycle decimation and periodic covariance [fdip-0057]AGENTDRAFTED
- November 1, 2026
Example. Cycle decimation and periodic covariance [fdip-0057]AGENTDRAFTED
- November 1, 2026
Take the unit-weight cycle on \(\mathbb Z/(2N)\), with \(N\ge 3\) and precision \(Q=L_{C_{2N}}+aI\), where \(a=m^2>0\). The group \(G=C_N\) acts by two-site rotations. It preserves the even retained vertices and the odd eliminated vertices. Write \(x_j=\phi _{2j}\), \(y_j=\phi _{2j+1}\) and \(q=2+a\); indices \(j\) lie in \(\mathbb Z/N\). For the shift \((Tz)_j=z_{j-1}\), the blocks are \[A=C=qI,\qquad B=-(I+T),\qquad B^*=-(I+T^{-1}).\] Thus the equivariant Schur formula gives \[\begin {aligned} S&=qI-q^{-1}(2I+T+T^{-1})\\ &=w'L_{C_N}+a'I,\\ w'&=\frac 1{2+a},\qquad a'=(2+a)-\frac 4{2+a} =\frac {a(a+4)}{a+2}>0. \end {aligned}\] Here \(L_{C_N}=2I-T-T^{-1}\). The restriction \(Q_{RR}=qI\) has no off-diagonal entries, while \(S\) has entries \(-1/q\) between adjacent retained vertices. The retained set is stable under \(G\), but the marginal precision is induced by elimination.
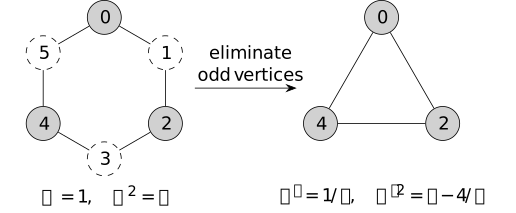
The six-cycle illustrates \(N=3\). Shaded even vertices remain; dashed odd vertices are integrated out. Each triangle edge has weight \(1/q\), and the mass squared changes from \(a\) to \(q-4/q\), with \(q=2+a\).
The finite Gaussian normalization is retained exactly: \(Z_Q=Z_CZ_S\) with \(Z_C=(2\pi/q)^{N/2}\), and the retained law is \(\mu _S\). The effective weight and mass are both part of this law. Dividing \(S\) by \(w'\) is useful for comparing its parameters, but changes the field covariance by a scalar unless the corresponding field rescaling is also made.
Put \(q=2\cosh \omega \) with \(\omega >0\). Then \[2+\frac {a'}{w'}=q^2-2=2\cosh (2\omega ).\] The doubled parameter has an exact finite-ring interpretation. For \(M\ge 3\), the covariance of precision \(w(2\cosh \eta \,I-T-T^{-1})\) on \(\mathbb Z/M\), with \(w,\eta >0\), is the periodic kernel \[\begin {aligned} K_{M,w,\eta }(r) &=\frac {e^{-\eta r}+e^{-\eta (M-r)}} {2w\sinh \eta \,(1-e^{-M\eta })},\\ &\hspace {24mm}0\le r\le M-1. \end {aligned}\] For the original and retained fields this gives \[(Q^{-1})_{0,2r} =K_{2N,1,\omega }(2r) =K_{N,w',2\omega }(r) =(S^{-1})_{0,r}.\] The equality is between covariances with their actual weights.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
On the integer line, put \(h(n)=e^{-\eta |n|}/(2w\sinh \eta )\). For \(n\ne 0\), the two geometric progressions give \(w(2\cosh \eta \,h(n)-h(n-1)-h(n+1))=0\). At \(n=0\) the expression equals \((2\cosh \eta -2e^{-\eta })/(2\sinh \eta )=1\). Periodize this identity by summing \(h(r+kM)\) over \(k\in \mathbb Z\); absolute convergence permits the finite difference operation under the sum. The result is the unit point source on \(\mathbb Z/M\), so the periodized kernel is the inverse of the positive precision. Summing the geometric series gives \(K_{M,w,\eta }\).
For \(M=2N\) and even separation \(2r\), the numerator and periodic denominator equal those for \(M=N\), \(\eta =2\omega \). Their remaining constants agree because \[2w'\sinh (2\omega ) =\frac {2\sinh (2\omega )}{2\cosh \omega } =2\sinh \omega .\] This proves the covariance identity directly, in agreement with Gaussian marginalization.
In the convention that correlation length is the reciprocal decay rate of these periodized exponential images, it changes from \(\xi =1/\omega \) fine lattice units to \(\xi '=1/(2\omega )=\xi / 2\) coarse lattice units. The finite ring has two winding directions, so its covariance is not a single exponential in separation. If the old spacing is \(\ell \), the new spacing is \(2\ell \); the physical decay length \(\ell / \omega =(2\ell )/(2\omega )\) is unchanged.
The bound \(N\ge 3\) keeps the reduced graph a simple cycle. At \(N=2\), \(T=T^{-1}\) and two eliminated vertices connect the same retained pair, producing two parallel edges of weight \(1/q\), or one edge of weight \(2/q\). At \(a=0\), the algebraic formula still gives \(w'=1/2\) and \(a'=0\), the two-resistors-in-series limit. The full precision then has a constant zero mode and no normalized full-space Gaussian law. Pinning or a mean-zero constraint must be specified as in constrained massless laws; the positive-mass covariance formula is not a finite limit on the full field space.
This is a direct cycle calculation within Kron reduction, the Schur reduction of graph Laplacians with possible positive diagonal terms. Closure follows from [dorfler2011kron, Lemma 2.1, pp. 5-6]. Successive and simultaneous eliminations agree by [dorfler2011kron, Lemma 3.3, p. 14]. In that source the diagonal mass corresponds to a shunt conductance or graph self-loop. In the incidence convention used here an edge with identical endpoints has zero difference; the mass is therefore kept as the separate term \(aI\). The source supplies the general reduction context, while the periodic covariance and scale statements are proved above.
Remark. Symmetry of a marginal and restriction of a precision [fdip-0058]AGENTDRAFTED
- November 1, 2026
Remark. Symmetry of a marginal and restriction of a precision [fdip-0058]AGENTDRAFTED
- November 1, 2026
The sector laws use an ordinary orthogonal finite-group action on a real field space and a strictly positive precision. These hypotheses allow independent Gaussian factors and equivariant elimination. They do not make every stable retained subspace a reducing subspace for the precision. A stable vertex set says that its coordinate projection commutes with the group action; cycle decimation shows that it need not commute with \(Q\). The resulting Schur precision can therefore differ from the compression \(Q_{RR}\). Commuting with the group action and commuting with \(Q\) are distinct conditions.
Three other representation-theoretic questions need additional data. Projective representations and twisted group algebras record a multiplier rather than an ordinary group action; the projective obstruction explains its role. Restriction to a normal subgroup and Clifford's homogeneity theorem concern constituents under a specified subgroup inclusion; this is Clifford theory of group representations, distinct from Clifford algebras. In positive characteristic, the averaging denominator or Gaussian measure used here may be absent. None of these is supplied by real isotypic factorization alone.
Configuration Clifford algebras [fdip-001B]AGENTDRAFTED
- October 20, 2026
Configuration Clifford algebras [fdip-001B]AGENTDRAFTED
- October 20, 2026
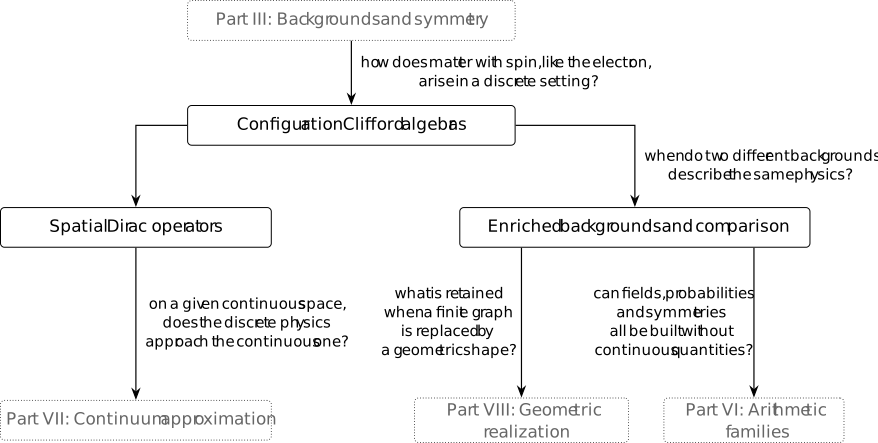
How might a discrete first-order equation acquire the internal components used to describe matter with spin? For two commuting centered differences, try \(D=a\nabla _1+b\nabla _2\). Relations \(a^2=b^2=I\) and \(ab+ba=0\) cancel the mixed term in its square. Real or complex scalars cannot satisfy them, but the two-by-two matrices \(X,Z\) do. This is an algebraic two-component example, not a derivation of electron spin. With these self-adjoint matrices and skew-adjoint centered differences, the positive square is \(-D^2\); it uses two-step shifts and differs from the nearest-neighbor Laplacian.
The common algebraic question is how a quadratic form can be encoded by products of generators. Here the configuration quadratic form determines a Clifford algebra through its square relation. Keeping the polar normalization explicit lets form-preserving maps act functorially, without identifying a quadratic map with a chosen coordinate array. This algebra encodes the supplied configuration form; it does not choose the spatial Clifford module used for Dirac operators.
Example. The configuration quadratic form and its polar forms [fdip-000O]AGENTDRAFTED
- October 17, 2026
Example. The configuration quadratic form and its polar forms [fdip-000O]AGENTDRAFTED
- October 17, 2026
For the alternating four-cycle, let \(V=\mathbb R^4\) be the space of vertex fields and let \(\delta _i(j)=\delta _{ij}\) be its coordinate vectors. These are distinct from the oriented edges \(e_i\) and the spectral vectors \(u_a\) of Example [fdip-0037]. With \(t,m>0\), put \(a=m^2\) and \(s=1+t+a\). The massive precision gives the quadratic form \[\begin {aligned} q_{t,m}(v)&=v^TQ_{t,m}v,\\ Q_{t,m}&=\begin {pmatrix} s&-1&0&-t\\-1&s&-t&0\\0&-t&s&-1\\-t&0&-1&s \end {pmatrix}. \end {aligned}\] The Euclidean action is \(\mathcal A(v)=q_{t,m}(v)/2\). The factor \(1/2\) belongs to the action; the quadratic form used below is \(q_{t,m}\) itself.
Write \(q=q_{t,m}\) and \(Q=Q_{t,m}\). The unhalved polar form and the half-polar form are respectively \[\begin {aligned} B_q(u,v)&=q(u+v)-q(u)-q(v)\\ &=2u^TQv,\\ b_q(u,v)&=\tfrac 12 B_q(u,v)=u^TQv. \end {aligned}\] Thus \(q(v)=b_q(v,v)\), while \(B_q(v,v)=2q(v)\). This is the polarization dictionary: the symmetric bilinear form called \(B\) by Meinrenken is \(b_q\), not \(B_q\). His Clifford relation uses \(2B\) [meinrenken2013clifford, Definition 2.1, p. 27].
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The matrix \(Q\) is symmetric. Expanding \((u+v)^TQ(u+v)\) and canceling the two diagonal terms gives \(u^TQv+v^TQu=2u^TQv\). This is bilinear, and \(q(cv)=c^2q(v)\) for every real \(c\), so \(q\) is a quadratic form. The edge energy also gives \[\begin {aligned} q(v)={}&(v_1-v_0)^2+t(v_2-v_1)^2\\ &{}+(v_3-v_2)^2+t(v_0-v_3)^2\\ &{}+m^2\sum _{i=0}^3v_i^2. \end {aligned}\] Every term is nonnegative. If \(v\ne 0\), the last term is positive because \(m>0\); hence \(q\) is positive definite.
Mathlib's Matrix.toQuadraticForm' constructs this
matrix quadratic form. Its underlying
LinearMap.BilinMap.toQuadraticMap sends a bilinear map
\(b\) to \(v\mapsto b(v,v)\); here \(b(u,v)=u^TQv\).
The definition QuadraticMap.polar is unhalved.
These generic constructions supply the conventions; the displayed
matrix and positivity calculation specify this example.
The 4 coordinates are configuration directions, one per vertex. Positive definiteness therefore describes a form on field space. It supplies no Lorentzian spacetime metric. Changing \(t,m\) changes this form and the Gaussian state, even though the half-turn action stays fixed.
Proposition. The Clifford algebra of the configuration form [fdip-000P]AGENTDRAFTED
- October 17, 2026
Proposition. The Clifford algebra of the configuration form [fdip-000P]AGENTDRAFTED
- October 17, 2026
Let \(k\) be a commutative ring, \(M\) a \(k\)-module and \(q:M\to k\) a quadratic form. Use the tensor algebra and the square-quotient convention for the Clifford algebra: \[\operatorname {Cl}(q)=T_k(M)/I_q,\] where \(I_q\) is the two-sided ideal generated by \(v\otimes v-q(v)1\) for all \(v\in M\). The canonical linear map \(\iota _q:M\to \operatorname {Cl}(q)\) satisfies \(\iota _q(v)^2=q(v)1\). Scalars in this formula mean their images under the algebra's structure map. No invertibility of \(2\) is required for this construction.
For every unital associative \(k\)-algebra \(A\), a linear map \(f:M\to A\) extends to a unique unital \(k\)-algebra homomorphism \(\widehat f:\operatorname {Cl}(q)\to A\) if and only if \[f(v)^2=q(v)1_A\qquad (v\in M).\] This is the Clifford lift and its universal property.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
Necessity follows by applying an algebra homomorphism to the square relation. For sufficiency, send a pure tensor to its ordered product, \[v_1\otimes \cdots \otimes v_r\longmapsto f(v_1)\cdots f(v_r),\] and send \(c\in k=T_k^0(M)\) to \(c1_A\). The product is multilinear because \(f\) is linear, multiplication in \(A\) is distributive, and the scalar images are central. The tensor-product universal property therefore gives a linear map on each tensor power. Their direct sum defines a linear map \(F:T_k(M)\to A\). Concatenation of pure tensors becomes multiplication of their ordered products. Distributivity then proves multiplicativity on all finite sums, and the degree-zero formula preserves the unit and scalars. Every generator of \(I_q\) maps to \(f(v)^2-q(v)1_A=0\); multiplicativity makes every element of the two-sided ideal map to zero. Thus \(F\) descends to \(\widehat f\). Every tensor is a finite linear combination of pure tensors, whose images in the quotient are products of the \(\iota _q(v)\). An algebra map with the prescribed generator values must have the displayed value on each such product and on every scalar. This proves uniqueness.
Linearity and the square relation give the anticommutator: \[\begin {gathered} \iota _q(u)\iota _q(v)+\iota _q(v)\iota _q(u)\\ =\bigl (q(u+v)-q(u)-q(v)\bigr )1\\ =B_q(u,v)1. \end {gathered}\] Indeed, expand \((\iota _q(u)+\iota _q(v))^2\) and subtract the two squares. This uses no division by \(2\). When \(2\) is invertible, \(b_q=B_q/2\) exists and the relation becomes \(\iota _q(u)\iota _q(v)+\iota _q(v)\iota _q(u)=2b_q(u,v)1\). Conversely that relation with \(u=v\) recovers the square relation by cancellation of \(2\). Thus the two presentations agree in this case. Without that hypothesis, the anticommutator alone need not recover the squares.
Meinrenken gives the bilinear presentation in
[meinrenken2013clifford, Definition 2.1, p. 27]
and the universal property in
[meinrenken2013clifford, Proposition 2.2 and Remark 2.2, p. 29].
His chapter assumes a finite-dimensional vector space over a
characteristic-zero field (p. 23); Remark 2.2 includes the ordinary
algebra formulation. The direct argument above supplies the stated
commutative-ring generality. Mathlib's
CliffordAlgebra.ι_sq_scalar,
CliffordAlgebra.lift,
CliffordAlgebra.lift_unique and
CliffordAlgebra.ι_mul_ι_add_swap
provide these respective generic square, extension, uniqueness and
unhalved-polar statements.
Now take the real configuration form and put \(c_i=\iota _q(\delta _i)\). Write \(\{x,y\}=xy+yx\) for the anticommutator. The matrix entries give \[\begin {aligned} c_i^2&=s1\quad (i=0,1,2,3),\\ \{c_0,c_1\}&=\{c_2,c_3\}=-2\,1,\\ \{c_1,c_2\}&=\{c_3,c_0\}=-2t\,1,\\ \{c_0,c_2\}&=\{c_1,c_3\}=0. \end {aligned}\] These follow from \(q(\delta _i)=Q_{ii}=s\) and \(b_q(\delta _i,\delta _j)=Q_{ij}\). In particular the squares are positive in this convention. The opposite-sign convention would use \(-q\).
For this real form, both the scalar map and \(\iota _q\) are
injective. Here is the exterior algebra argument of
[meinrenken2013clifford, Proposition 2.1, p. 28], with its
operator identities made explicit. On \(\bigwedge V\), let
\(\epsilon (v)\omega =v\wedge \omega \), and define contraction by
\[d_v(1)=0,\]
\[\begin {gathered}
d_v(w_1\wedge \cdots \wedge w_r)\\
=\sum _{j=1}^r(-1)^{j-1}b_q(v,w_j)\\
\quad \cdot w_1\wedge \cdots \widehat {w_j}\cdots \wedge w_r.
\end {gathered}\]
The alternating multilinear expression defines a linear operator
on the exterior algebra. Exterior alternation gives
\(\epsilon (v)^2=0\). In \(d_v^2\), each pair of removed positions
occurs twice with opposite signs and the same scalar coefficient,
so \(d_v^2=0\). Separating the first term of \(d_v(v\wedge \omega )\)
gives
\[d_v\epsilon (v)+\epsilon (v)d_v=b_q(v,v)I.\]
Consequently \(C(v)=\epsilon (v)+d_v\) is linear in \(v\) and
\(C(v)^2=q(v)I\). The universal property gives a unital algebra
map \(\rho :\operatorname {Cl}(q)\to \operatorname {End}_{\mathbb R}(\bigwedge V)\).
It satisfies \(\rho (\iota _q(v))1=v\) and \(\rho (r1)1=r1\).
Since \(\bigwedge ^1 V=V\) and \(\bigwedge ^0V=\mathbb R\),
these equations prove both injections. The contraction identities
are also recorded in [meinrenken2013clifford, Section 2.1.3, pp. 25-26].
TauCeti's CliffordAlgebra.ι_injective and
CliffordAlgebra.algebraMap_injective
give the corresponding injections for an arbitrary quadratic form
over a commutative ring with invertible \(2\).
The exterior action just used proves faithfulness on vectors and scalars; it does not assert that \(\rho \) is a faithful algebra representation. Nor does this construction select a physical spinor module, a positive expectation on the Clifford algebra, or a differential operator. The earlier Gaussian expectation acts on polynomial observables of vertex fields; an expectation on this new algebra would require a specified construction.
Theorem. Form-preserving maps and the half-turn Clifford automorphism [fdip-000Q]AGENTDRAFTED
- October 17, 2026
Theorem. Form-preserving maps and the half-turn Clifford automorphism [fdip-000Q]AGENTDRAFTED
- October 17, 2026
Let \(k\) be a commutative ring, \(M_1,M_2\) be \(k\)-modules with quadratic forms \(q_1,q_2\), and let \(f:M_1\to M_2\) be linear with \[q_2(f(v))=q_1(v)\qquad (v\in M_1).\] This form-preserving map induces a unique unital \(k\)-algebra map \[\operatorname {Cl}(f):\operatorname {Cl}(q_1)\longrightarrow \operatorname {Cl}(q_2)\] satisfying \(\operatorname {Cl}(f)(\iota _1(v))=\iota _2(f(v))\). This is the underlying Clifford map in isometry transport. It requires no inverse for \(f\). The defining square is:
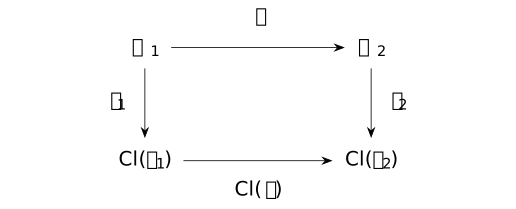
The top and vertical arrows are linear maps; the bottom arrow is a unital algebra map. The square commutes as a square of linear maps. For composable form-preserving maps \(f,g\), \[\begin {aligned} \operatorname {Cl}(\operatorname {id})&=\operatorname {id},\\ \operatorname {Cl}(g\circ f)&=\operatorname {Cl}(g)\circ \operatorname {Cl}(f). \end {aligned}\] If \(f\) is a linear isomorphism, \(\operatorname {Cl}(f)\) is an algebra isomorphism with inverse \(\operatorname {Cl}(f^{-1})\).
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The linear map \(v\mapsto \iota _2(f(v))\) has square \(q_2(f(v))1=q_1(v)1\). Apply the universal property to obtain the unique extension. For the identity, the induced map and the identity algebra map agree on every generator, hence are equal by uniqueness. For composition, both proposed maps send \(\iota _1(v)\) to \(\iota _3(g(f(v)))\); uniqueness again proves equality. If \(f\) is invertible, set \(v=f^{-1}(w)\) in form preservation to get \(q_1(f^{-1}(w))=q_2(w)\). Thus the inverse is also form-preserving. The two composition identities give mutually inverse algebra maps.
Meinrenken derives this functoriality for bilinear-form-preserving
maps in [meinrenken2013clifford, Section 2.2.2, p. 29].
Over his characteristic-zero field, polarization equates that
condition with preservation of \(q\). The proof here applies
directly to quadratic forms over commutative rings. Mathlib's
CliffordAlgebra.map,
CliffordAlgebra.map_apply_ι,
CliffordAlgebra.map_id,
CliffordAlgebra.map_comp_map and
CliffordAlgebra.equivOfIsometry
provide the extension, generator equation, identity, composition
and inverse construction. Their input is a linear map preserving
the quadratic form, or a linear equivalence for the last result.
Return to \(q=q_{t,m}\) on \(V=\mathbb R^4\). The same half-turn sends \(\delta _i\) to \(\delta _{i+2}\), with indices modulo \(4\). It satisfies \(P^2=I\) and \(P^TQP=Q\), so \(q(Pv)=q(v)\). Therefore \[\begin {aligned} \Theta &=\operatorname {Cl}(P),\\ \Theta (c_i)&=c_{i+2},\qquad \Theta ^2=\operatorname {id}. \end {aligned}\] The matrix equation follows by shifting both indices of \(Q\) by two: its diagonal, its paired off-diagonal entries \(-1\) and \(-t\), and its zeros are preserved. Composition gives \(\Theta ^2=\operatorname {Cl}(P^2)=\operatorname {id}\). Moreover \(\delta _0\ne \delta _2\), so injectivity of \(\iota _q\) gives \(c_0\ne c_2\). Thus \(\Theta \) is nontrivial and has order exactly two.
The real half-turn sectors
\(V_\pm =\ker (P\mp I)\) are orthogonal for \(b_q\). Indeed,
\(P^TQP=Q\) gives \(b_q(Pu,Pv)=b_q(u,v)\). For
\(u\in V_+\) and \(v\in V_-\), the left side is
\(b_q(u,-v)=-b_q(u,v)\). Over \(\mathbb R\) this forces
\(b_q(u,v)=0\), and hence
\[\iota _q(u)\iota _q(v)=-\iota _q(v)\iota _q(u).\]
This is the generic orthogonality consequence
CliffordAlgebra.ι_mul_ι_comm_of_isOrtho.
The cross-sector vector generators anticommute; the direct sum
of sectors does not make them commuting factors of an ordinary
tensor-product algebra.
Preservation of the form is essential. Compare \(q_{1,1}\) and \(q_{2,1}\) while keeping the coordinate labels unchanged. At \(\delta _0\), \[q_{1,1}(\delta _0)=3,\qquad q_{2,1}(\delta _0)=4.\] Thus the identity linear map is not form-preserving. Write \(c_i^{(1)},c_i^{(2)}\) for the two sets of generators. A unital real algebra map with \(c_i^{(1)}\mapsto c_i^{(2)}\) would send \((c_0^{(1)})^2=3\,1\) to \((c_0^{(2)})^2=3\,1\), but the target square is \(4\,1\). Its injective scalar map rules this out. This excludes precisely the unchanged-label assignment. It does not exclude other isometries between the positive forms or an abstract isomorphism of their Clifford algebras.
The construction transports a supplied configuration form and its discrete symmetry. It supplies no spacetime derivative, Dirac operator or Lorentzian interpretation. Those structures need additional data and compatibility conditions.
Spatial Dirac operators [fdip-001C]AGENTDRAFTED
- October 20, 2026
Spatial Dirac operators [fdip-001C]AGENTDRAFTED
- October 20, 2026
A periodic spatial grid carries a different Clifford-module problem from the configuration space. A separately chosen complex Clifford module couples to centered differences. The square and Fourier blocks of the resulting Dirac operator can be calculated exactly. Its zero modes and comparison with nearest-neighbor differences show why a Clifford construction alone does not determine the desired kinetic operator or a continuum limit.
Definition. A centered Dirac operator on a finite periodic grid [fdip-000R]AGENTDRAFTED
- October 17, 2026
Definition. A centered Dirac operator on a finite periodic grid [fdip-000R]AGENTDRAFTED
- October 17, 2026
To couple Clifford multiplication to spatial differences, fix an integer \(d\ge 1\) and periods \(N_j\ge 3\) for \(1\le j\le d\). The periodic grid and its scalar fields are \[\begin {aligned} \Lambda &=\prod _{j=1}^d\mathbb Z/N_j\mathbb Z,\\ M&=\prod _{j=1}^d N_j,\qquad H=\mathbb C^\Lambda . \end {aligned}\] Write \(e_j\in \Lambda \) for the unit step in coordinate \(j\). Addition is periodic and the lattice spacing is one. Extend the counting pairing to the Hermitian inner product \[\langle f,g\rangle _H =\sum _{x\in \Lambda }\overline {f(x)}g(x),\] conjugate-linear in the first slot.
The spatial quadratic form is \[q_{\mathrm {sp}}(z)=\sum _{j=1}^d z_j^2 \qquad (z\in \mathbb C^d).\] It is distinct from the Hermitian norm squared \(\sum _j|z_j|^2\) and from the real four-field configuration form. For example, at \(i\varepsilon _1\), where \(\varepsilon _j\) is the standard basis of \(\mathbb C^d\), the quadratic value is \(-1\) and the Hermitian norm squared is \(1\). The grid steps \(e_j\), these complex coordinate vectors, and the 4 configuration coordinates have different carriers.
Choose \(S=(\mathbb C^2)^{\otimes d}\) with its standard tensor
basis and product Hermitian inner product. In the
Pauli convention, take
\[X=\begin {pmatrix}0&1\\1&0\end {pmatrix},\qquad
Z=\begin {pmatrix}1&0\\0&-1\end {pmatrix},\]
and put \(I=I_2\) and
\[\gamma _j=Z^{\otimes (j-1)}\otimes X
\otimes I^{\otimes (d-j)}.\]
An empty tensor product contributes the scalar identity.
Direct multiplication gives \(X^*=X\), \(Z^*=Z\),
\(X^2=Z^2=I\) and \(XZ=-ZX\). Ordinary tensor products obey
\[\begin {aligned}
(A\otimes B)^*&=A^*\otimes B^*,\\
(A\otimes B)(C\otimes E)&=AC\otimes BE.
\end {aligned}\]
The product formula follows on pure tensors, which span; the
adjoint formula follows from the product inner product on such
tensors. Thus \(\gamma _j^*=\gamma _j\) and
\(\gamma _j^2=I_S\). For \(i<j\), the only anticommuting slot is
\(i\), where \(X\) meets \(Z\). Before it both factors are \(Z\);
after it at least one factor is \(I\). Hence
\[\gamma _i\gamma _j+\gamma _j\gamma _i
=2\delta _{ij}I_S.\]
Mathlib's Matrix.kronecker,
Matrix.mul_kronecker_mul,
Matrix.conjTranspose_kronecker and
Matrix.one_kronecker_one give the corresponding
matrix construction and identities. Iterating them requires
identifying the product-index bases.
The complex-linear map \(c:\mathbb C^d\to \operatorname {End}_{\mathbb C}(S)\)
defined by \(c(z)=\sum _j z_j\gamma _j\) satisfies
\[\begin {aligned}
c(z)^2&=\sum _j z_j^2 I_S\\
&\quad +\sum _{i<j}z_i z_j
(\gamma _i\gamma _j+\gamma _j\gamma _i)\\
&=q_{\mathrm {sp}}(z)I_S.
\end {aligned}\]
The Clifford universal property therefore gives a
unique unital complex-algebra map
\[\begin {aligned}
\rho :\operatorname {Cl}(q_{\mathrm {sp}})&\longrightarrow
\operatorname {End}_{\mathbb C}(S),\\
\rho (\iota (\varepsilon _j))&=\gamma _j.
\end {aligned}\]
This makes \(S\) a Clifford module, in the
module-map convention.
The ordinary-algebra universal property is stated in
[meinrenken2013clifford, Proposition 2.2 and Remark 2.2, p. 29].
Its bilinear form is \(b(z,w)=\sum _j z_jw_j\), with relation
\(uv+vu=2b(u,v)1\); see
[meinrenken2013clifford, Definition 2.1, p. 27].
The displayed square identity is precisely the input required
by CliffordAlgebra.lift over \(\mathbb C\).
This chosen module is reducible. The involution \[J=I^{\otimes (d-1)}\otimes X\] commutes with every \(\gamma _j\): its last factor meets either \(I\) or \(X\), and its other factors are identities. Its two eigenspaces are \[S_\pm =(\mathbb C^2)^{\otimes (d-1)} \otimes \mathbb C(1,\pm 1).\] Both are nonzero and have dimension \(2^{d-1}\). Commutation with \(J\) makes them invariant under every generator and hence under the generated Clifford action. We use \(\dim S=2^d\); no minimality or faithfulness of this representation is needed.
Extend the cyclic shift coordinatewise: \[(T_j f)(x)=f(x+e_j).\] Its inverse shifts by \(-e_j\). Reindexing \(y=x+e_j\) gives \[\begin {aligned} \langle T_jf,g\rangle _H &=\sum _y\overline {f(y)}g(y-e_j)\\ &=\langle f,T_j^{-1}g\rangle _H. \end {aligned}\] Thus \(T_j^*=T_j^{-1}\), so \(T_j\) is unitary. The shifts and their inverses commute, since addition in \(\Lambda \) commutes. The centered differences are the endomorphisms \[\nabla _j=(T_j-T_j^{-1})/2.\] They commute and satisfy \(\nabla _j^*=-\nabla _j\). Their source and target are both \(H\), unlike a general vertex-to-edge incidence map.
Set \(K=S\otimes _{\mathbb C}H\), with \(\langle s\otimes f,t\otimes g\rangle _K =\langle s,t\rangle _S\langle f,g\rangle _H\). Identify \(s\otimes f\) with the field \(x\mapsto f(x)s\). The centered Dirac operator is \[D=\sum _{j=1}^d\gamma _j\otimes \nabla _j.\] Equivalently, \[\begin {aligned} (D\psi )(x) &=\frac 12\sum _{j=1}^d\gamma _j\psi (x+e_j)\\ &\quad -\frac 12\sum _{j=1}^d\gamma _j\psi (x-e_j). \end {aligned}\] For \(d=1\), this is \(X\) applied to the ordinary centered difference of a two-component field. Wingate's gauge-covariant centered difference reduces to this difference when all links are one and the spacing is one [wingate2025lattice, Section 9.1, Equation (9.2), p. 19]. The finite grid and tensor module here are specified directly; this construction introduces no Grassmann integration or gauge field. The Lorentz-sign gamma algebra is a different choice of form, scalar field and representation.
Theorem. The Dirac square and its finite Fourier blocks [fdip-000S]AGENTDRAFTED
- October 17, 2026
Theorem. The Dirac square and its finite Fourier blocks [fdip-000S]AGENTDRAFTED
- October 17, 2026
For the periodic grid and Clifford module, the centered Dirac operator is skew-adjoint and has square \[\begin {aligned} D^*&=-D,\\ D^2&=I_S\otimes \sum _{j=1}^d\nabla _j^2,\\ -D^2&=\frac 14 I_S\otimes \sum _{j=1}^d(2I_H-T_j^2-T_j^{-2}). \end {aligned}\] In particular \(-D^2=D^*D\) is positive semidefinite. Its complete finite Fourier decomposition has blocks \[\begin {aligned} D(p)&=i\sum _{j=1}^d\gamma _j\sin p_j,\\ -D(p)^2&=s(p)I_S,\\ s(p)&=\sum _{j=1}^d\sin ^2p_j, \end {aligned}\] where \(p_j=2\pi r_j/N_j\) and \(0\le r_j<N_j\). The sine convention agrees with the free propagator in [wingate2025lattice, Section 9.1, Equations (9.6)-(9.7), p. 20] after setting the spacing to one. The finite decomposition and square are proved below.
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The tensor adjoint formula and \(\gamma _j^*=\gamma _j\), \(\nabla _j^*=-\nabla _j\) give \((\gamma _j\otimes \nabla _j)^* =-\gamma _j\otimes \nabla _j\); adding proves \(D^*=-D\). In the square, every diagonal term is \(\gamma _j^2\otimes \nabla _j^2=I_S\otimes \nabla _j^2\). For \(i<j\), the paired off-diagonal terms are \[\begin {gathered} \gamma _i\gamma _j\otimes \nabla _i\nabla _j +\gamma _j\gamma _i\otimes \nabla _j\nabla _i\\ =(\gamma _i\gamma _j+\gamma _j\gamma _i) \otimes \nabla _i\nabla _j=0, \end {gathered}\] using commutation of the differences and anticommutation of the distinct gamma matrices. This proves the square formula. Expanding \(\nabla _j^2\) gives \((T_j^2-2I_H+T_j^{-2})/4\). Finally \(\langle \psi ,-D^2\psi \rangle _K =\langle D\psi ,D\psi \rangle _K\ge 0\).
Let \(\mathcal R=\prod _j\{0,\ldots ,N_j-1\}\) and, for \(r\in \mathcal R\), define the normalized character function \[\chi _r(x)=M^{-1/2} \exp \left (i\sum _{j=1}^d p_jx_j\right ).\] Choose integer representatives for \(x_j\). Changing one by \(N_j\) multiplies the exponential by \(\exp (2\pi i r_j)=1\); changing \(r_j\) by \(N_j\) likewise multiplies it by \(\exp (2\pi i x_j)=1\). Thus the function depends only on the residue classes.
For \(r,t\in \mathcal R\), put \[\zeta _j=\exp \left (\frac {2\pi i(t_j-r_j)}{N_j}\right ).\] The counting inner product factors: \[\langle \chi _r,\chi _t\rangle _H =M^{-1}\prod _{j=1}^d\sum _{k=0}^{N_j-1}\zeta _j^k.\] If \(t_j=r_j\), then \(\zeta _j=1\) and the inner sum is \(N_j\). Otherwise the chosen range of labels gives \(\zeta _j\ne 1\) and \(\zeta _j^{N_j}=1\), so \[(1-\zeta _j)\sum _{k=0}^{N_j-1}\zeta _j^k =1-\zeta _j^{N_j}=0.\] Division by \(1-\zeta _j\) makes that sum zero. Consequently \(\langle \chi _r,\chi _t\rangle _H=\delta _{rt}\). There are \(M\) such functions, and \(\dim _{\mathbb C}H=M\), as witnessed by the vertex indicators. Orthonormality gives linear independence, so these functions form a complete basis.
For a spinor-valued field, the Fourier transform and inverse therefore are \[\begin {aligned} \widehat \psi (r) &=M^{-1/2}\sum _{x\in \Lambda } e^{-i\sum _jp_jx_j}\psi (x),\\ \psi (x) &=M^{-1/2}\sum _{r\in \mathcal R} e^{i\sum _jp_jx_j}\widehat \psi (r). \end {aligned}\] For scalar fields the coefficient is \(\widehat f(r)=\langle \chi _r,f\rangle _H\); applying that basis expansion in each standard coordinate of \(S\) proves the two vector-valued formulas. Thus \[K=\bigoplus _{r\in \mathcal R} S\otimes \mathbb C\chi _r.\] The forward shift has \(T_j\chi _r=e^{ip_j}\chi _r\), hence \(\nabla _j\chi _r=i\sin p_j\,\chi _r\). Each displayed summand is invariant under \(D\), with block \(D(p)=i\sum _j\gamma _j\sin p_j\). Expanding its square using the same anticommutators gives \(D(p)^2=-s(p)I_S\).
Mathlib's LinearMap.adjoint and
LinearMap.adjoint_inner_right give the finite-dimensional
adjoint and its characterizing identity;
LinearMap.adjoint_comp reverses composition.
The relevant formal inner-product structure is the counting
Euclidean space, for example a \(\operatorname {PiLp}(2)\)
model. The raw function type's default supremum norm cannot
silently replace that structure. The translation and tensor
identifications are the direct calculations above.
Mathlib's ZMod.dft,
ZMod.dft_apply and ZMod.invDFT_apply
provide the one-coordinate Fourier equivalence: its forward
sum has a negative exponent and no normalizing factor, while
its inverse has a positive exponent and factor \(N^{-1}\).
Iterating over coordinates and scaling the forward transform
by \(M^{-1/2}\) gives the conventions above.
AddChar.wInner_cWeight_eq_boole gives generic
character orthogonality for the normalized average inner
product. Here the unscaled characters have counting norm
\(\sqrt M\); the factor \(M^{-1/2}\) makes them orthonormal.
Their explicit enumeration, the shift eigenvalues and the
spinor blocks are supplied by this finite proof.
Proposition. Zero modes and the nearest-neighbor mismatch [fdip-000T]AGENTDRAFTED
- October 17, 2026
Proposition. Zero modes and the nearest-neighbor mismatch [fdip-000T]AGENTDRAFTED
- October 17, 2026
On the periodic grid, let \(e\) be the number of even periods among \(N_1,\ldots ,N_d\). The centered Dirac operator has exactly \(2^e\) zero momentum blocks and \[\dim _{\mathbb C}\ker D=2^{d+e}.\] This is the kernel dimension for the explicitly chosen reducible module \(S\), whose dimension is \(2^d\). The unit-weight graph Laplacian \[L_{\mathrm {nn}}=\sum _{j=1}^d (2I_H-T_j-T_j^{-1})\] has only the zero momentum in its scalar kernel. Moreover \(-D^2\ne I_S\otimes L_{\mathrm {nn}}\) on every permitted grid, including grids with all periods odd. These are finite consequences of the Fourier blocks; the centered-difference convention comes from [wingate2025lattice, Section 9.1, Equations (9.2), (9.6)-(9.7), pp. 19-20].
Proof.
- October 17, 2026
Proof.
- October 17, 2026
The forward-difference factorization from Lemma [fdip-0014], applied in each coordinate, gives \[L_{\mathrm {nn}}=\sum _j(T_j-I_H)^*(T_j-I_H).\] For \(N_j\ge 3\), each undirected nearest-neighbor edge occurs once in the corresponding squared-difference energy. On the character with momentum \(p\), the eigenvalue is \[\begin {aligned} \ell (p)&=\sum _j(2-2\cos p_j)\\ &=4\sum _j\sin ^2(p_j/2). \end {aligned}\] The positive Dirac square has scalar block \(s(p)=\sum _j\sin ^2p_j\). The double-angle identity gives \[\ell (p)-s(p)=4\sum _j\sin ^4(p_j/2).\] Choose \(r_1=1\) and the other labels zero. Since \(N_1\ge 3\), \(\sin (\pi/N_1)>0\), so the difference is strictly positive on that block. This proves the operator mismatch.
Every summand of \(s(p)\) is nonnegative. Hence \(s(p)=0\) exactly when each \(\sin p_j=0\). In the range \(0\le r_j<N_j\), this means \(r_j=0\), or \(r_j=N_j/2\) when \(N_j\) is even. There are exactly \(2^e\) choices. On each such block \(D(p)=0\) on all of \(S\). Every other block is invertible, with two-sided inverse \[D(p)^{-1}=-D(p)/s(p),\] because \(D(p)^2=-s(p)I_S\). Completeness of the Fourier basis therefore gives \(\dim \ker D=2^e\dim S=2^{d+e}\). In contrast, \(\ell (p)=0\) forces \(r_j=0\) for every \(j\); thus \(\dim \ker (I_S\otimes L_{\mathrm {nn}})=2^d\).
For \(d=1,N=4\), the alternating scalar field \(a(x)=(-1)^x\) has momentum \(p=\pi \). Its centered difference is zero, whereas \(L_{\mathrm {nn}}a=4a\). Consequently every field \(x\mapsto a(x)v\), \(v\in S\), is killed by \(D\). Together with the constant fields these give the four-dimensional kernel. Write \(K_2=(2I_H-T^2-T^{-2})/4\), so \(-D^2=I_S\otimes K_2\). The two scalar Laplacians have the following weighted graphs:
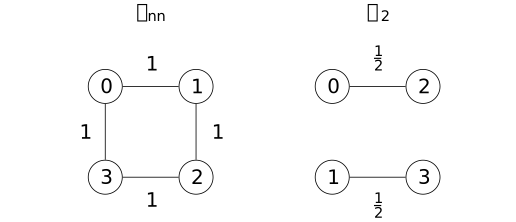
Left: the 4 unit-weight nearest-neighbor edges. Right: the two-step edges, with vertices rearranged to display the parity classes \(\{0,2\}\) and \(\{1,3\}\). At period \(4\), \(T^2=T^{-2}\), so \(K_2=(I_H-T^2)/2\): the two shift contributions of weight \(1/4\) combine into one undirected edge of weight \(1/2\) for each opposite pair. The alternating field is constant on each right-hand component, explaining its zero energy there.
For \(d=1,N=3\), momentum \(p=2\pi/3\) instead gives \[s(p)=\tfrac 34,\qquad \ell (p)=3.\] Only \(r=0\) is a zero momentum, yet the operators still differ. Thus extra exact zero momenta occur precisely when at least one period is even, whereas the square mismatch always occurs. The excluded case \(N=2\) has \(T=T^{-1}\), making its centered difference identically zero.
The finite kernel dimension above is not a physical species or chirality count. Friedan's Nielsen-Ninomiya theorem concerns free fermions on the infinite lattice \(\mathbb Z^d\) for odd \(d\), with continuous torus momenta. Its Hamiltonian is quadratic, phase invariant, translation invariant and local, with a Hermitian momentum symbol. The locality discussion reduces the Hamiltonian requirement to continuity; the internal-charge projections must be smooth. The zero set is finite and isolated, with specified relativistic Clifford-linear behavior near each zero. Under these hypotheses the total chiral index vanishes separately for each charge [friedan1982nielsen, Sections 1-2, pp. 481-484; Equations (6), (10)-(11)]. A finite sampled grid in arbitrary dimension with the chosen reducible module computes a different quantity. The odd-period example neither contradicts that theorem nor establishes a continuum limit. No Lorentzian model or factorization of the earlier weighted precision is supplied by this centered operator.
Enriched backgrounds and comparison [fdip-001E]AGENTDRAFTED
- October 20, 2026
Enriched backgrounds and comparison [fdip-001E]AGENTDRAFTED
- October 20, 2026
Which data must a comparison preserve for observables to survive? The finite background, its reference pairing and retained split already distinguish a relabeling from an arbitrary field map. The cycle trace ratio gives an observable with which to test a proposed comparison.
The enriched groupoid records allowed arrows and the data they preserve. Scalar invariants descend along those arrows without classifying all backgrounds. Quadratic isometry can forget the reference pairing or retained projection even while transporting a positive Gaussian law. Its Clifford functoriality therefore need not retain all the information required for these observables.
Example. The groupoid of enriched four-cycle backgrounds [fdip-000X]AGENTDRAFTED
- October 18, 2026
Example. The groupoid of enriched four-cycle backgrounds [fdip-000X]AGENTDRAFTED
- October 18, 2026
A classification of Gaussian backgrounds must retain the maps that transport their observables. Consider the alternating four-cycle with vertices \(V=\mathbb Z/4\mathbb Z\), forward edges \(e_i:i\to i+1\), and weights \((a,b,a,b)\), where \(a,b>0\). Choose \(m>0\) and one of \(R_0=\{0,2\}\), \(R_1=\{1,3\}\) as retained vertices. Write \(x=(a,b,m,R_j)\) and let \(X\) be the set of all these tuples. The tuple specifies a finite Gaussian background, together with its named half-turn.
More explicitly, retain the carrier, counting reference pairing, weight matrix \(W_x=\operatorname {diag}(a,b,a,b)\), and \[L_x=B^TW_xB,\qquad Q_x=L_x+m^2I.\] Here \((B\phi )_i=\phi _{i+1}-\phi _i\). For \(\phi \ne 0\), \[\begin {aligned} \phi ^TQ_x\phi &=\sum _iw_i(\phi _{i+1}-\phi _i)^2\\ &\quad +m^2\|\phi \|^2>0. \end {aligned}\] The normalized Gaussian \(\mu _{Q_x}\) is determined by this precision and coordinate Lebesgue measure. Also retain the measurable coordinate projection \(\pi _{R_j}:\mathbb R^V\to \mathbb R^{R_j}\) and the named action \(\rho (h)\delta _i=\delta _{i+2}\) of \(C_2=\{1,h\}\). The vertex basis \(\delta _i(v)=\mathbf 1_{v=i}\) is distinct from the edges \(e_i\) and the spectral vectors \(u_a\). These structures are specified or determined, rather than additional freely variable coordinates of \(X\).
Allow rotations and reflections of the underlying cycle. Put \[D_4=\langle r,s\mid r^4=s^2=1,\ srs=r^{-1}\rangle ,\] where \(r(i)=i+1\) and \(s(i)=-i\). A reflection reverses the forward orientation. Thus these arrows use the signed endpoint convention and extend the earlier strictly directed exact relabelings. For \(g=r^ks^\varepsilon \), with \(k\in \mathbb Z/4\) and \(\varepsilon \in \{0,1\}\), set \[\begin {aligned} g(i)&=k+(-1)^\varepsilon i,\\ P_g\delta _i&=\delta _{g(i)},\\ \tau _g(i)&=\begin {cases}k+i&\varepsilon =0,\\k-i-1&\varepsilon =1,\end {cases}\\ U_g\eta _i&=(-1)^\varepsilon \eta _{\tau _g(i)}. \end {aligned}\] Here \(\eta _i\) is the edge-field coordinate basis. All indices are modulo \(4\). The 8 vertex maps are distinct because their values at \(0,1\) determine \(k,\varepsilon \).
The edge indexed by \(\tau _g(i)\) has endpoints \(g(i),g(i+1)\), in forward order for a rotation and reverse order for a reflection. Consequently, for every field \(\phi \), \[\begin {aligned} (BP_g\phi )_{\tau _g(i)}&=(-1)^\varepsilon (B\phi )_i,\\ BP_g&=U_gB. \end {aligned}\] If \(k'\) denotes a second group element, endpoint transport and multiplication of the orientation signs give \[P_{k'g}=P_{k'}P_g,\qquad U_{k'g}=U_{k'}U_g.\] For an explicit group-law check, composition of \((k,\varepsilon )\) followed by \((\ell ,\eta )\) gives \[\begin {aligned} (\ell ,\eta )(k,\varepsilon ) &=(\ell +(-1)^\eta k,\eta +\varepsilon ). \end {aligned}\] The second coordinate is taken modulo two. Both coordinate maps are orthogonal, and their inverses are indexed by \(g^{-1}\).
Transport weights by \(W_{gx}=U_gW_xU_g^T\) and the retained set by \(R\mapsto gR\). The signs cancel in the diagonal weight matrix. The weights swap exactly when \(k+\varepsilon \) is odd, while \(R_j\mapsto R_{j+k\bmod 2}\). In particular, \[\begin {aligned} r(a,b,m,R_j)&=(b,a,m,R_{j+1}),\\ s(a,b,m,R_j)&=(b,a,m,R_j). \end {aligned}\] The family is closed under these maps, with mass unchanged. Using \(BP_g^T=U_g^TB\) gives \[\begin {aligned} L_{gx}&=B^TU_gW_xU_g^TB=P_gL_xP_g^T,\\ Q_{gx}&=P_gQ_xP_g^T. \end {aligned}\] Moreover \(g(i+2)=g(i)+2\), so every arrow commutes with the same named half-turn: \(P_g\rho (h)=\rho (h)P_g\).
Form the action groupoid \(D_4\ltimes X\) by setting \[\operatorname {Hom}(x,y)=\{g\in D_4:g x=y\}.\] The group element remains part of an arrow. Compose \(g:x\to y\) and \(k:y\to z\) as \(kg:x\to z\); the action law gives its target. The identity is \(1:x\to x\), the inverse is \(g^{-1}:gx\to x\), and the two inverse identities and associativity follow from the group laws. Thus every arrow is invertible, as in [stacks2017stacks, Definition 4.2.5], Tag 0018. The source, target and composition follow the set-level pattern in [stacks2017stacks, Lemma 78.15.1], Tag 0444; that lemma is stated for algebraic spaces, whereas the axioms here were checked directly for sets. \(X\) is infinite, but each orbit and its restricted groupoid is finite.
The stabilizer of the weights at \(a\ne b\) is \(\{1,r^2,rs,r^3s\}\cong C_2\times C_2\); preserving weights requires \(k+\varepsilon \) even. The stabilizer of either retained partition is \(\{1,r^2,s,r^2s\}\cong C_2\times C_2\), since preserving the partition requires \(k\) even. Intersecting these conditions gives the following automorphism groups. When \(a\ne b\), \[\operatorname {Aut}(x)=\{1,r^2\}\cong C_2.\] When \(a=b\), \[\begin {aligned} \operatorname {Aut}(x)&=\{1,r^2,s,r^2s\}\\ &\cong C_2\times C_2. \end {aligned}\] At equal weights the first condition disappears. In each four-element subgroup the two indicated generators are distinct commuting involutions. No further condition comes from the named half-turn, which commutes with all 8 elements. The kernel \(\{1,r^2\}\) of the parameter action is retained as distinct arrows: \(P_{r^2}\delta _0=\delta _2\ne \delta _0\).
For unequal weights the orbit consists of both weight orders and both partitions, at fixed mass. Write \(x_j=(a,b,m,R_j)\) and \(y_j=(b,a,m,R_j)\). The drawing shows selected generator arrows; it does not draw all arrows or isotropy loops.
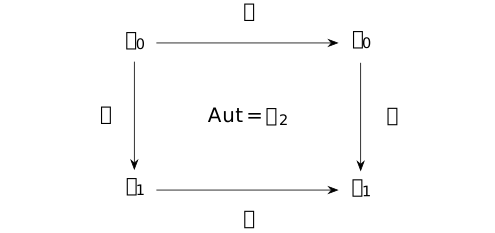
At \(a=b\), put \(z_j=(a,a,m,R_j)\). There are two objects, each with automorphism group \(C_2\times C_2\):
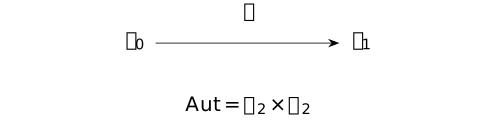
The generators \(s,r\) reach every displayed object; there are exactly 4 objects when \(a\ne b\) and two when \(a=b\). It follows in both directions that the coarse isomorphism classes are \((m,\{a,b\})\). The coarse orbit set forgets the isotropy just computed, as in Example [fgap-000P]. On the strict slice \((1,t,m,R_0)\), isomorphism requires the same mass and \(\{1,t\}=\{1,t'\}\), whose products give \(t=t'\). Thus reciprocal parameters are not identified there unless \(t=1\). This is a set-level groupoid, within the boundary before stacks.
Mathlib's CategoryTheory.ActionCategory constructs
the generic action category; a group action makes it a groupoid.
CategoryTheory.ActionCategory.stabilizerIsoEnd
identifies the stabilizer monoid with endomorphisms, which are invertible
in the group case. MulAction.orbitRel and
MulAction.stabilizer provide the generic coarse relation
and subgroup. DihedralGroup.card gives 8 elements
at \(n=4\), and DihedralGroup.center_eq_closure_of_even_ne_two
gives the central half-turn. In its constructor convention our
\(r^ks\) corresponds to \(\texttt {sr}(-k)\), while \(r^k\)
corresponds to \(\texttt {r}(k)\). These declarations support the
group constructions; the particular parameter action, signed incidence
and stabilizer intersections are the calculations above.
Proposition. Scalar descent and transport of Gaussian observables [fdip-000Y]AGENTDRAFTED
- October 18, 2026
Proposition. Scalar descent and transport of Gaussian observables [fdip-000Y]AGENTDRAFTED
- October 18, 2026
On the enriched four-cycle groupoid, the trace ratio, with the cycle values, is a scalar on isomorphism classes, while covariance and effective precision are transported operators on their specified field spaces. For \(x=(a,b,m,R)\) write \(C_x=Q_x^{-1}\). If \(g:x\to y\), then \[\begin {aligned} C_y&=P_gC_xP_g^T,\\ (P_g)_*\mu _{Q_x}&=\mu _{Q_y},\\ \langle F\rangle _{Q_y}&=\langle F\circ P_g\rangle _{Q_x}. \end {aligned}\] The last identity holds for Borel \(F\in L^1(\mu _{Q_y})\); integrability is equivalent to that of \(F\circ P_g\) in the source law. These statements use the inverse-precision covariance and Gaussian transport, including their normalization.
Proof.
- October 18, 2026
Proof.
- October 18, 2026
The groupoid construction proves \(Q_y=P_gQ_xP_g^T\) and \(P_g^{-1}=P_g^T\). Inverting gives the covariance equation. The normalized density in dimension \(4\) is \[d\mu _Q(\phi )=\frac {\sqrt {\det Q}}{(2\pi )^2} e^{-\phi ^TQ\phi /2}\,d\phi .\] Set \(\psi =P_g\phi \). The absolute Jacobian is one. The exponent is now \(-\psi ^TQ_y\psi /2\). Also \(\det Q_y=\det Q_x\), proving the pushforward identity. Apply the same substitution to \(|F|\) first, then to the positive and negative parts when finite, to prove the expectation statement. Transport composes because \(P_{kg}=P_kP_g\).
Transport does not imply equality of labeled arrays. At \((a,b,m)=(1,2,1)\), the spectral covariance formula gives \[\begin {aligned} (C_x)_{01} &=\tfrac 14(1-\tfrac 13+\tfrac 15-\tfrac 17)\\ &=\tfrac {19}{105},\\ (P_rC_xP_r^T)_{01} &=\tfrac 14(1+\tfrac 13-\tfrac 15-\tfrac 17)\\ &=\tfrac {26}{105}. \end {aligned}\] The second entry is the old \((3,0)\) entry. The observable's coordinate labels must move with the field to preserve its expectation.
Let \(D=V\setminus R\). In retained/eliminated coordinates write \[\begin {aligned} Q_x&=\begin {pmatrix}A&H\\H^T&C_D\end {pmatrix},\\ S_R(x)&=A-HC_D^{-1}H^T. \end {aligned}\] This Schur complement is the positive precision of the marginal. The restrictions of \(g\) give permutation isometries \(P_R:\mathbb R^R\to \mathbb R^{gR}\) and \(P_D:\mathbb R^D\to \mathbb R^{gD}\). Then \[\begin {aligned} S_{gR}(y)&=P_RS_R(x)P_R^T,\\ S_{gR}(y)^{-1}&=P_RS_R(x)^{-1}P_R^T,\\ \pi _{gR}P_g&=P_R\pi _R. \end {aligned}\] Thus the marginal laws are compatible on the changing retained spaces.
Proof.
- October 18, 2026
Proof.
- October 18, 2026
The transformed blocks are \[\begin {aligned} A'&=P_RAP_R^T,\\ H'&=P_RHP_D^T,\\ C_D'&=P_DC_DP_D^T. \end {aligned}\] Substitution, using \(P_D^TP_D=I\), gives \[\begin {aligned} S_{gR}(y)&=A'-H'(C_D')^{-1}(H')^T\\ &=P_R(A-HC_D^{-1}H^T)P_R^T. \end {aligned}\] Inversion proves the covariance equation. The projection identity holds on each vertex coordinate vector. Consequently \[\begin {aligned} (P_R)_*\mu _{S_R(x)} &=(P_R\pi _R)_*\mu _{Q_x}\\ &=(\pi _{gR}P_g)_*\mu _{Q_x}\\ &=(\pi _{gR})_*\mu _{Q_y} =\mu _{S_{gR}(y)}. \end {aligned}\] Restrictions of composable permutations compose on these spaces, so the identities are compatible with composition.
For either opposite pair in ascending coordinate order, put \(d=a+b+m^2\). Direct block multiplication gives \[\begin {aligned} A=C_D&=dI_2,\\ H&=-\begin {pmatrix}a&b\\b&a\end {pmatrix},\\ S_R(x)&=\begin {pmatrix}\alpha &-\beta \\-\beta &\alpha \end {pmatrix},\\ \alpha &=d-\frac {a^2+b^2}{d},\\ \beta &=\frac {2ab}{d}. \end {aligned}\] This particular two-by-two array is unchanged by swapping weights or retained coordinates. That special equality does not make general operator assignments scalar invariants; the full covariance entries above already differ.
For the nonzero positive semidefinite \(L_x\), define \[\mathcal R(x)=\frac {\operatorname {tr}(L_x^2)} {\bigl (\operatorname {tr}L_x\bigr )^2}.\] Then \(\mathcal R(gx)=\mathcal R(x)\), and \[\mathcal R(a,b)=\frac {a^2+ab+b^2}{2(a+b)^2}.\] This scalar descends to the coarse orbit set but does not classify the enriched objects.
Proof.
- October 18, 2026
Proof.
- October 18, 2026
Trace cyclicity gives \(\operatorname {tr}(P_gMP_g^T)=\operatorname {tr}M\). Also \(L_{gx}^2=P_gL_x^2P_g^T\); hence both traces are preserved. For the explicit value, the 4 orthonormal vectors \(u_0,u_1,u_2,u_3\) from Example [fdip-0037] remain eigenvectors after replacing weights \((1,t)\) by \((a,b)\), with eigenvalues \(0,2a,2b,2a+2b\). Substituting the alternating entries of \(L_x\) verifies each eigenvector equation. Therefore \[\begin {aligned} \operatorname {tr}L_x&=4(a+b)>0,\\ \operatorname {tr}(L_x^2)&=8(a^2+ab+b^2). \end {aligned}\] These spectral trace identities use [boyd2004convex, Appendix A.5.2, pp. 646-647]. The positive denominator justifies the division. In particular \[\begin {aligned} \mathcal R(1,1)&=\frac 38,\\ \mathcal R(1,2)&=\frac 7{18},\\ \frac 7{18}-\frac 38&=\frac 1{72}. \end {aligned}\] The ratio ignores \(m\), so backgrounds of different masses have the same value. It also satisfies \(\mathcal R(1,t)=\mathcal R(1,1/t)\), although the strict slice objects are inequivalent for \(t\ne 1\) by Example [fdip-000X].
Now forget mass, state and partition and admit positive scaling of the Laplacian, as in the broader comparison: \[L'=cP_gLP_g^T,\qquad c>0.\] The numerator of \(\mathcal R\) gains \(c^2\), while its denominator gains the same factor. Thus the ratio is invariant under this different relation. A weight-swapping relabeling followed by \(c=1/t\) sends \(L(1,t)\) to \(L(1,1/t)\). Reciprocal parameters are identified in this reduced problem only; no scale arrow has been added to the original Gaussian groupoid. At fixed mass, \(cL+m^2I\ne cQ\) for \(c\ne 1\). If one instead rescales the entire precision to \(cQ\), then \[\begin {aligned} (cQ)^{-1}&=c^{-1}Q^{-1},\\ cA-(cH)(cC_D)^{-1}(cH)^T&=cS_R. \end {aligned}\] Raw covariance and effective precision therefore are not scale invariants. Any normalized operator ratio would need its own definition and scaling proof.
Mathlib's Matrix.trace_units_conj and
Matrix.trace_smul support the trace conjugacy and scaling
identities. Matrix.reindexLinearEquiv and
Matrix.reindexRingEquiv supply coordinate infrastructure.
TauCeti's
TauCeti.Probability.map_affine_multivariateGaussian
allows positive semidefinite covariance and an arbitrary rectangular
linear map. Set its mean and translation to zero, its covariance
to \(Q_x^{-1}\), and its linear map to \(P_g\) or \(\pi _R\).
The precision-density identification and the Schur and groupoid
computations above remain separate obligations.
Example. Quadratic isometry forgets the reference pairing and projection [fdip-000Z]AGENTDRAFTED
- October 18, 2026
Example. Quadratic isometry forgets the reference pairing and projection [fdip-000Z]AGENTDRAFTED
- October 18, 2026
The enriched classification changes if one keeps only a positive quadratic form and permits every linear isometry. Any two positive symmetric matrices \(Q_1,Q_2\) of the same size define isometric quadratic spaces, even when their counting-relative spectra and retained observables differ.
[boyd2004convex, Appendix A.5.2, pp. 646-647] gives the symmetric spectral decomposition and positive square root used below to construct the isometry.
For \(Q=O\operatorname {diag}(\lambda _i)O^T\), with \(O\) orthogonal and every \(\lambda _i>0\), define \[\begin {aligned} Q^{1/2}&=O\operatorname {diag}(\sqrt {\lambda _i})O^T,\\ A=Q^{-1/2}&=O\operatorname {diag}(\lambda _i^{-1/2})O^T. \end {aligned}\] Direct multiplication gives \(A^TQA=I\). More generally, \[\begin {aligned} T&=Q_2^{-1/2}Q_1^{1/2},\\ T^TQ_2T &=Q_1^{1/2}Q_2^{-1/2}Q_2Q_2^{-1/2}Q_1^{1/2}\\ &=Q_1. \end {aligned}\] The map \(T\) is invertible. This calculation does not require \(Q_1Q_2=Q_2Q_1\). Thus positive quadratic forms have one linear-isometry class in each fixed dimension.
The reference pairing changes under the same substitution \(\phi =Az\): its matrix becomes \[H'=A^TIA=Q^{-1},\] while the action form has matrix \(I\). If that transported pairing is retained, its relative operator is \((H')^{-1}I=Q\), preserving the original spectrum. In general simultaneous transport of a positive reference pairing \(H\) and an action form \(Q\) gives \[\begin {aligned} H'&=A^THA,\qquad Q'=A^TQA,\\ (H')^{-1}Q'&=A^{-1}(H^{-1}Q)A. \end {aligned}\] Similarity preserves the spectrum. Replacing \(H'\) by \(I\) after normalizing \(Q\) discards this data; it is not simultaneous transport of the pair.
For the four-cycle with \(a=m=1\), compare \(b=1\) and \(b=2\). The spectral calculation gives respectively \[\begin {aligned} \operatorname {spec}(Q_1)&=\{1,3,3,5\},\\ \operatorname {spec}(Q_2)&=\{1,3,5,7\}. \end {aligned}\] These forms are linearly isometric by \(T\), but cannot be conjugate by a counting-orthogonal map, since their spectra differ. In particular they are not compatible relabelings. Their trace ratios also differ by \(1/72\).
The same isometry gives a concrete obstruction to the retained projection, even though it preserves the named half-turn. In the common orthonormal spectral basis \(u_0,u_1,u_2,u_3\), the matrix of \(T\) is \[\operatorname {diag}\bigl (1,1,\sqrt {3/5},\sqrt {5/7}\bigr ).\] The half-turn is diagonal in this basis as well, so \(T\rho (h)=\rho (h)T\). Returning to vertex coordinates gives \[T_{01}=\frac {\sqrt {3/5}-\sqrt {5/7}}4\ne 0,\] because \(3/5\ne 5/7\). For \(R=R_0\), one has \(\pi _R\delta _1=0\), whereas the zeroth component of \(\pi _RT\delta _1\) is nonzero. Hence no linear map \(T_R\) can satisfy \(\pi _RT=T_R\pi _R\). Also \(T^TT\) has eigenvalues \(1,1,3/5,5/7\), so \(T\) fails to preserve the counting pairing. These are separate failures of the enriched-arrow conditions.
A Jacobian magnitude different from one does not obstruct normalized Gaussian transport. If \(T^TQ_2T=Q_1\), then \[\det Q_1=(\det T)^2\det Q_2.\] For \(y=T\phi \), the exponent in the normalized density becomes \(-y^TQ_2y/2\); its coefficient after the reference change of variables is \[\frac {\sqrt {\det Q_1}}{(2\pi )^{n/2}|\det T|} =\frac {\sqrt {\det Q_2}}{(2\pi )^{n/2}}.\] Therefore \(T_*\mu _{Q_1}=\mu _{Q_2}\). Equivalently, \(Q_2^{-1}=TQ_1^{-1}T^T\) is the covariance transport law. For \(A=Q^{-1/2}\), the Jacobian magnitude \(|\det A|=(\det Q)^{-1/2}\) is exactly absorbed by normalization, even when it differs from one. The loss is the discarded pairing, carrier and retained projection, not a failure of normalized probability transport.
TauCeti's
Matrix.PosDef.exists_generalLinearGroup_mul_transpose_eq
provides an invertible factor \(C\) with \(Q=CC^T\) for a real
positive-definite matrix on a finite index set. For a bare witness
of that conclusion the normalizer is \(C^{-T}\), since
\[(C^{-T})^TQ C^{-T}=C^{-1}CC^TC^{-T}=I.\]
The theorem's proof chooses the symmetric positive square root,
but its existential conclusion does not assert symmetry of \(C\).
One therefore cannot infer that \(C^{-1}\) is the normalizer
from the factorization alone. Its separate
TauCeti.Probability.map_affine_multivariateGaussian
supports Gaussian transport in covariance parameters, after the
precision-density identification. Neither declaration supplies the
enriched classification or projection obstruction.
By Clifford functoriality, an isometry of these configuration forms also induces an algebra isomorphism. Since the positive forms already lie in one isometry class, keeping only the abstract quadratic space, or its isometry-functorial Clifford algebra, cannot recover the discarded reference pairing, carrier and projection. This argument does not infer a quadratic isometry from an arbitrary Clifford-algebra isomorphism. Retaining the enriched objects and their specified relabeling arrows prevents the demonstrated collapse; it supplies no continuum or physical selection map.
Arithmetic families [fdip-001D]AGENTDRAFTED
- October 20, 2026
Arithmetic families [fdip-001D]AGENTDRAFTED
- October 20, 2026
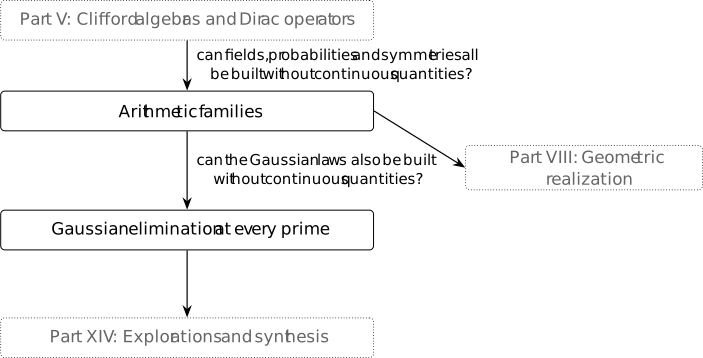
Which constructions survive if field values use finite arithmetic instead of the real numbers? For each prime \(p\), the finite field \(\mathbb F_p\) gives such a value system. Comparing it with a real model requires a specified arithmetic family and control of denominators. The four-cycle coefficients give an arithmetic family over \(\mathbb Z[1/2,t]\). Scalar extension organizes its Clifford algebras, while the form, elimination map and observable ratio each impose their own domain. Bad fibers distinguish those domains concretely. This base excludes characteristic two, where the earlier half-turn example shows how an algebra can survive while its sector decomposition changes.
The rational comparison uses Gaussian elimination and the reference pairing and trace conventions. It distinguishes the information in a quadratic center character from the independently defined trace observable. These arithmetic families also supply the fiber-constancy criterion used by the realization comparison.
With rational positive-definite precision in counting coordinates, the Gaussian covariance \(Q^{-1}\) is rational, although its normalized real law still uses real integration. Which moment and partition-function identities have arithmetic counterparts? The prime-by-prime Gaussian chapter gives the moment rule over a ring. The finite-field partition functions are not constructed there.
Example. An arithmetic family for the alternating four-cycle [fdip-000U]AGENTDRAFTED
- October 18, 2026
Example. An arithmetic family for the alternating four-cycle [fdip-000U]AGENTDRAFTED
- October 18, 2026
The configuration form has polynomial coefficients when the mass is fixed by \(m^2=1\). Keeping the weight \(t\) as a variable records which specializations preserve the form, its half-turn, and the operations on it. Put \(A_0=\mathbb Z[1/2,t]\) and \(s=t+2\). In the coordinate basis \(\delta _0,\ldots ,\delta _3\), set \[Q(t)=\begin {pmatrix} s&-1&0&-t\\ -1&s&-t&0\\ 0&-t&s&-1\\ -t&0&-1&s \end {pmatrix},\] \[\begin {aligned} q(x)&=x^TQ(t)x,\\ b(x,y)&=x^TQ(t)y. \end {aligned}\] Thus \(q\) is twice the earlier quadratic action. Its half-polar form is \(b\); its full polar form has matrix \(2Q\): \[q(x+y)-q(x)-q(y)=2b(x,y).\] These conventions also apply after changing the coefficient ring.
Let \(H\) have the 4 unnormalized columns \[H=\begin {pmatrix} 1&1&1&1\\ 1&-1&1&-1\\ 1&-1&-1&1\\ 1&1&-1&-1 \end {pmatrix}.\] They are neither the coordinate vectors \(\delta _i\) nor the normalized real spectral vectors \(u_a\) of the cycle spectral calculation. Direct multiplication gives \[\begin {aligned} H^TH&=4I,\\ QH&=H\operatorname {diag}(1,3,2t+1,2t+3). \end {aligned}\] Since \(2\) is a unit in \(A_0\), \(H^{-1}=H^T/4\). Similarity therefore gives \[\Delta :=\det Q=3(2t+1)(2t+3).\] The congruence formula retains a factor 4: \[H^TQH=4\operatorname {diag}(1,3,2t+1,2t+3).\] These are polynomial matrix identities, independent of any order or positivity on the coefficient ring.
The nondegenerate arithmetic base is \[R_q=A_0[\Delta ^{-1}],\qquad X_q=\operatorname {Spec}R_q,\] with quadratic module \((R_q^4,q)\). Here \(A[g^{-1}]\) denotes localization of a commutative ring \(A\) by the powers of \(g\). The spectrum \(\operatorname {Spec}A\) has prime ideals as points; its standard open \[D_{\operatorname {Spec}A}(g) =\{\mathfrak p:g\notin \mathfrak p\}\] has regular functions \(A[g^{-1}]\). The structure sheaf given by these rings and their restriction maps makes the spectrum an affine scheme, in the sense of [stacks2017stacks, Section 26.5], Tag 01HR.
Every factor of the unit product \(\Delta \) is a unit in \(R_q\): an inverse for a factor is the product of the other factors times \(\Delta ^{-1}\). The displayed similarity then makes \(Q\) invertible. Both \(Q\) and \(2Q\) identify \(R_q^4\) with its dual. This localization selects nondegenerate forms; the Clifford quotient exists over \(A_0\) even before it is made. Inverting \(2\) separately excludes characteristic two, although \(\Delta \equiv 1\pmod 2\). Inverting \(\Delta \) removes characteristic three entirely. In any residue field of characteristic other than two or three, the excluded parameters are \(-1/2\) and \(-3/2\); they are distinct because their difference is one.
For example, evaluation at \(t=1\) gives \(\det Q=45\). It is admissible over \(\mathbb Q\) and over \(\mathbb F_{11}\), but not over \(\mathbb F_5\). An arithmetic family therefore retains information that a single real matrix does not.
The same half-turn \[P(x_0,x_1,x_2,x_3)=(x_2,x_3,x_0,x_1)\] satisfies \(P^2=I\) and \(P^TQP=Q\): shifting both indices by two preserves each entry of \(Q\). By the universal property, the assignment \[\iota _q(x)\longmapsto \iota _q(Px)\] extends to an algebra endomorphism of \(\operatorname {Cl}_{R_q}(q)\). Its square fixes scalars and all vector generators, hence is the identity. It defines a \(C_2\) action by automorphisms. The coordinate basis, reference pairing \(x^Ty\), and retained partition remain additional supplied data.
Retain coordinates \((0,2)\) and eliminate \((1,3)\) as in the four-cycle Schur calculation. To distinguish its denominator from that of the trace ratio on its unit domain, put \(f=t+1\) and define \[\begin {aligned} R_{\mathrm {elim}}&=R_q[s^{-1}],\\ R_{\mathrm {obs}}&=R_{\mathrm {elim}}[f^{-1}],\\ X_{\mathrm {elim}}&=\operatorname {Spec}R_{\mathrm {elim}},\\ X_{\mathrm {obs}}&=\operatorname {Spec}R_{\mathrm {obs}},\\ U_R&=D_{X_q}(f). \end {aligned}\] The open immersions identify \[\begin {aligned} X_{\mathrm {elim}}&=D_{X_q}(s),\\ X_{\mathrm {obs}}&=D_{X_{\mathrm {elim}}}(f) =D_{X_q}(sf),\\ X_{\mathrm {obs}}&=X_{\mathrm {elim}}\cap U_R. \end {aligned}\] The independent ratio locus \(U_R\) is not identified with \(X_{\mathrm {obs}}\); at \(t=-2\), the ratio exists while the selected elimination fails.
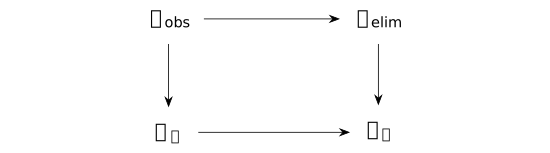
All 4 arrows are inclusions of open subschemes. The square
commutes and its upper-left open is the intersection of the
other two opens inside \(X_q\). The localization homeomorphism is
[stacks2017stacks, Lemma 10.17.6], Tag 00E4.
The structure-sheaf construction in
[stacks2017stacks, Section 26.5], Tag 01HR
upgrades it to an open immersion: on a standard open inside
\(D(g)\), successive localization gives the same ring and
restriction map on either side. These identifications agree on
intersections, so the structure sheaves agree. Mathlib's
AlgebraicGeometry.Scheme.isOpenImmersion_SpecMap_localizationAway
and AlgebraicGeometry.Scheme.Hom.opensRange_localizationAway
give this generic map and its exact ambient image. The
determinant and the particular family above are the direct
calculations made here.
Theorem. Clifford algebras under scalar extension [fdip-000V]
L∃∀NAGENTDRAFTED
- October 18, 2026
Theorem. Clifford algebras under scalar extension [fdip-000V]
L∃∀NAGENTDRAFTED
- October 18, 2026
Let \(R\) be a commutative ring in which \(2\) is a unit, \(M\) any \(R\)-module with quadratic form \(q\), and \(A\) any commutative \(R\)-algebra. Extend the symmetric half-polar form \[b(v,w)=\frac {q(v+w)-q(v)-q(w)}2\] to \(M_A=A\otimes _R M\), and let \(q_A\) be its diagonal. Thus \[q_A(a\otimes v)=a^2q(v),\] where \(q(v)\) on the right is mapped into \(A\). There is a canonical \(A\)-algebra isomorphism \[\begin {aligned} \beta _A:A\otimes _R\operatorname {Cl}_R(q) &\longrightarrow \operatorname {Cl}_A(q_A),\\ \beta _A(a\otimes \iota _q(v)) &=a\,\iota _{q_A}(1\otimes v). \end {aligned}\] No flatness, nondegeneracy, finite generation, or injectivity of \(R\to A\) is required. This extends the displayed field case of scalar extension to the declared commutative rings, using the same universal property.
Proof.
- October 18, 2026
Proof.
- October 18, 2026
The \(R\)-linear map \(v\mapsto \iota _{q_A}(1\otimes v)\) has square \(q(v)1\), so the universal property extends it to an \(R\)-algebra map out of \(\operatorname {Cl}_R(q)\). Central \(A\)-scalars then extend it to \(\beta _A\). The algebra structure on the tensor product uses \[(a\otimes c)(a'\otimes c')=aa'\otimes cc'.\] It is well-defined because the \(R\)-scalars are central.
Conversely, the balanced bilinear assignment \((a,v)\mapsto a\otimes \iota _q(v)\) gives an \(A\)-linear map \[j:M_A\longrightarrow A\otimes _R\operatorname {Cl}_R(q).\] Write \(\iota =\iota _q\) and let \[\begin {aligned} B_q(v,w)&=q(v+w)\\ &\quad -q(v)-q(w)\\ &=2b(v,w) \end {aligned}\] be the full polar form. The defining square relation gives \[\iota (v)\iota (w)+\iota (w)\iota (v)=B_q(v,w)1.\] For an arbitrary finite sum \(x=\sum _i a_i\otimes v_i\), write \(w_i=\iota (v_i)\). Then \[\begin {aligned} j(x)^2 &=\sum _i a_i^2\otimes w_i^2\\ &+\sum _{i<j}a_i a_j\otimes (w_iw_j+w_jw_i)\\ &=\Bigl (\sum _i a_i^2q(v_i)\\ &\quad +\sum _{i<j}a_i a_j B_q(v_i,v_j)\Bigr )1\\ &=q_A(x)1. \end {aligned}\] Every tensor is such a finite sum; the cross terms are part of the square condition. Thus \(j\) extends to an \(A\)-algebra map in the opposite direction. Both composites fix scalars and vector generators. In the tensor-product algebra, \(a\otimes 1\) and \(1\otimes \iota (v)\) generate; in the other algebra, the vectors \(\iota _{q_A}(x)\) and scalars generate. The composites are therefore identities.
Mathlib's marked equivalence has the reverse direction,
\[\operatorname {Cl}_A(q_A)
\simeq A\otimes _R\operatorname {Cl}_R(q).\]
Its inverse is \(\beta _A\), and
CliffordAlgebra.ofBaseChange_tmul_ι
gives the displayed generator formula.
QuadraticForm.baseChange constructs \(q_A\); its
QuadraticForm.baseChange_tmul computes pure tensors.
These declarations have exactly the commutative-ring and
invertible-two hypotheses above. The marker concerns the
generic algebra equivalence, not the arithmetic domain
calculations or the sheaf multiplication below.
Scalar extension is compatible with a further commutative
algebra \(A\to B\). Identify
\[\begin {aligned}
B\otimes _A(A\otimes _R M)&\longrightarrow B\otimes _R M,\\
b\otimes (a\otimes v)&\longmapsto ba\otimes v.
\end {aligned}\]
The inverse inserts \(1\) in the middle tensor factor.
Under this identification the direct and successive Clifford
maps both send \(b\otimes (a\otimes \iota _q(v))\) to
\(ba\,\iota _{q_B}(1\otimes v)\). These elements and scalars
generate, proving equality of the algebra maps. TauCeti's
QuadraticForm.baseChangeBaseChange
uses the inverse identification, from direct to successive
extension. With compatible \(R\)- and \(A\)-algebra structures
on \(B\), its
CliffordAlgebra.ofBaseChangeAux_baseChange
states the same compatibility in that direction.
For an \(R\)-linear form-preserving map \(P:M\to M\), put \(P_A(a\otimes v)=a\otimes Pv\). The two orders of applying \(\beta _A\) and the induced Clifford map both take \(a\otimes \iota _q(v)\) to \(a\,\iota _{q_A}(1\otimes Pv)\). Generation again proves equivariance. In particular the arithmetic half-turn and its \(C_2\) action commute with every allowed scalar extension.
Apply this to \(C=\operatorname {Cl}_{R_q}(q)\) on the
arithmetic base \(X_q\). Write
\(\mathcal O_{X_q}\) for its structure sheaf: regular functions
on \(D_{X_q}(g)\) form \((R_q)_g\). The
associated module sheaf \(\widetilde C\) has
\[\Gamma (D_{X_q}(g),\widetilde C)
=C_g\simeq (R_q)_g\otimes _{R_q}C.\]
Its restriction maps are the localization maps; compatible
local sections glue uniquely. This construction and the
standard-open formula are
[stacks2017stacks, Section 26.5 and Lemma 26.5.4], Tag 01HR.
Mathlib's AlgebraicGeometry.tilde, with its
standard-open localized-module instance, supplies the underlying
module sheaf. It does not by itself give the algebra structure.
Multiplication and unit on a standard open are \[\frac {c}{g^m}\frac {d}{g^n} =\frac {cd}{g^{m+n}},\qquad 1=\frac 11.\] The denominators are central, so these operations are well-defined even though \(C\) need not be commutative. Restriction maps preserve them. On an arbitrary open, cover by standard opens and multiply the restrictions of two sections. The products agree on overlaps, so the module-sheaf axiom glues them uniquely; the same argument glues the unit. Associativity, additivity, the unit law and central \(\mathcal O_{X_q}\) action hold locally and hence globally. Thus \(\widetilde C\) is a sheaf of unital associative \(\mathcal O_{X_q}\)-algebras. No spectrum of the noncommutative algebra \(C\) is taken.
The isomorphisms \(\beta _{(R_q)_g}\) identify these standard-open sections with \[\operatorname {Cl}_{(R_q)_g}(q_g).\] Scalar-tower compatibility makes the identifications commute with restrictions. This constructs the Clifford algebra sheaf of \(\mathcal O_{X_q}^4\) with matrix \(Q\). The half-turn acts on every localization by the same generator formula and commutes with restrictions, giving a \(C_2\) action on the sheaf. Restricting to \(X_{\mathrm {elim}}\) or \(X_{\mathrm {obs}}\) uses exactly these base-change maps.
At the real specialization \(t=1\), put \(q_1(x)=x^TQ(1)x\) and let \(c_i=\iota _{q_1}(\delta _i)\) with the coordinate notation of the configuration Clifford algebra. Then \[c_i^2=3\,1,\qquad c_ic_j+c_jc_i=2Q(1)_{ij}\,1.\] The map \(\beta _{\mathbb R}\) identifies these relations with \(\mathbb R\otimes _{R_q}C\); direct evaluation or evaluation through either localization gives the same algebra and action. This evaluation is not injective: it kills the nonzero element \(t-1\) of \(R_q\). The isomorphism requires no injectivity. The effective rank-two form has its own Clifford algebra on \(X_{\mathrm {elim}}\); it is separate from this rank-4 construction.
Proposition. Different domains for the form, elimination and trace ratio [fdip-000W]AGENTDRAFTED
- October 18, 2026
Proposition. Different domains for the form, elimination and trace ratio [fdip-000W]AGENTDRAFTED
- October 18, 2026
On the arithmetic family, a nondegenerate full form need not permit a chosen elimination, and an invertible effective form need not give a regular trace ratio. With \(s=t+2\), \(f=t+1\) and \(\Delta =3(2t+1)(2t+3)\), the exact regular loci in \(X_q\) are \[\begin {aligned} \text {Schur matrix:}&\quad X_{\mathrm {elim}}=D_{X_q}(s),\\ \text {trace ratio:}&\quad U_R=D_{X_q}(f). \end {aligned}\] Their common domain is \(X_{\mathrm {obs}}=D_{X_q}(sf)\). These claims follow from the calculations below, extending the real Schur example and trace-ratio calculation over the declared rings. The intrinsic trace ratio requires a unit trace: \(\operatorname {tr}L=4f\) is a unit exactly when \(f\) is, since \(2\) is already inverted.
Proof.
- October 18, 2026
Proof.
- October 18, 2026
Order coordinates by retained \((0,2)\) and eliminated \((1,3)\). The diagonal blocks of \(Q\) are \(A=C_{\mathrm {block}}=sI_2\), and the off-diagonal block is \[B=\begin {pmatrix}-1&-t\\-t&-1\end {pmatrix}.\] On \(R_{\mathrm {elim}}\), the Schur matrix is \[\begin {aligned} S&=A-BC_{\mathrm {block}}^{-1}B^T\\ &=\frac 1s\begin {pmatrix}4t+3&-2t\\-2t&4t+3\end {pmatrix}. \end {aligned}\] Indeed \(BB^T\) has diagonal \(1+t^2\) and off-diagonal \(2t\), and \(s^2-(1+t^2)=4t+3\). Moreover \[\det S=\frac {(4t+3)^2-4t^2}{s^2} =\frac {\Delta }{s^2},\] a unit in \(R_{\mathrm {elim}}\). On \(R_{\mathrm {elim}}^2\), define \(q_{\mathrm {eff}}(y)=y^TSy\); its half-polar matrix is \(S\). Thus both \(q\) and \(q_{\mathrm {eff}}\) are nondegenerate on this open. On the positive real locus, \(q_{\mathrm {eff}}/2\) is the quadratic part of the effective action; the Gaussian normalization constant is additional.
The domain \(R_q\) embeds in its fraction field, so these entries can be tested in each local ring. If a prime \(\mathfrak p\) contains \(s\), the off-diagonal numerator \(-2t\) is congruent to \(4\) modulo \(\mathfrak p\) and is a unit in \((R_q)_{\mathfrak p}\). If \((-2t)/s\) were regular there, multiplication by \(s\) would equate an element of the maximal ideal with a unit. This is impossible. On \(D_{X_q}(s)\) every entry is regular. Hence this is the exact regular locus of the displayed Schur matrix.
For \(L=Q-I\), the diagonalization in Example [fdip-000U] gives eigenvalues \(0,2,2t,2t+2\). Therefore \[\begin {aligned} \operatorname {tr}L&=4(t+1),\\ \operatorname {tr}(L^2)&=8(t^2+t+1),\\ R(t)&=\frac {\operatorname {tr}(L^2)}{(\operatorname {tr}L)^2} =\frac {t^2+t+1}{2(t+1)^2}. \end {aligned}\] The numerator is \(f^2-f+1\). At every prime containing \(f\), it has residue \(1\), so is a unit in the local ring. Regularity of \(R\) there would make \[2f^2R=f^2-f+1\] an equality of an element of the maximal ideal and a unit, again impossible. Where \(f\) is invertible the formula is regular. Thus the exact ratio locus is \(U_R\), and its intersection with \(X_{\mathrm {elim}}\) is \(X_{\mathrm {obs}}\). The interpretation of these localizations as regular functions is [stacks2017stacks, Lemma 26.5.4], Tag 01HR.
The half-turn restricts to \(J=\left (\begin {smallmatrix}0&1\\1&0\end {smallmatrix}\right )\) on both coordinate blocks. The equal diagonal and equal off-diagonal entries of \(S\) give \(J^TSJ=S\). Retained projection \(\pi \) satisfies \(\pi P=J\pi \), but is not an isometry: \(q(\delta _1)=s\) is a unit on \(R_{\mathrm {elim}}\), whereas \(\pi \delta _1=0\). Thus Clifford functoriality supplies no map induced by this projection. The effective rank-two Clifford algebra and the full rank-4 algebra are different constructions.
Three rational specializations separate the domains:
- At \(t=-2\), \(\det Q=9\) and \(R=3/2\), but \(C_{\mathrm {block}}=0\). This point belongs to \(U_R\) inside \(X_q\) and lies outside \(X_{\mathrm {elim}}\).
- At \(t=-1\), \(\det Q=-3\), \(C_{\mathrm {block}}=I_2\), and \[\begin {aligned} S&=\begin {pmatrix}-1&2\\2&-1\end {pmatrix},\\ \det S&=-3. \end {aligned}\] This point belongs to \(X_{\mathrm {elim}}\), but the trace ratio has a pole, so it lies outside \(X_{\mathrm {obs}}\).
- At \(t=1\), \(\det Q=45\), \(C_{\mathrm {block}}=3I_2\), and \[\begin {aligned} S&=\frac 13\begin {pmatrix}7&-2\\-2&7\end {pmatrix},\\ \det S&=5,\qquad R=\frac 38. \end {aligned}\] This point belongs to \(X_{\mathrm {obs}}\).
For real \(t=\tau \), the matrix \(H/2\) is orthogonal, and the 4 eigenvalues of \(Q(\tau )\) are \(1,3,2\tau +1,2\tau +3\). They are all positive exactly when \(\tau >-1/2\). The running weighted graph assumes the smaller domain \(\tau >0\). Each such evaluation sends \(2,\Delta ,s,f\) to nonzero reals and extends uniquely to \[R_{\mathrm {obs}}\longrightarrow \mathbb R,\qquad t\longmapsto \tau .\] It gives \(\operatorname {Spec}\mathbb R\to X_{\mathrm {obs}}\) and recovers \(Q(\tau ),S(\tau ),P,J,R(\tau )\). The Clifford base-change isomorphism transports their full-form algebra and symmetry; it does not require evaluation to be injective. Gaussian integration and the normalized marginal apply on this positive real locus. Algebraic invertibility alone gives neither positivity nor a probability measure over the arithmetic base.
This family retains a parameter, residue characteristics, and distinct regularity domains. It does not select a unique arithmetic realization. For example, at \(t=1\) modulo \(11\), \(\Delta =45\), \(s=3\), and \(f=2\) are all nonzero. The point therefore lies in \(X_{\mathrm {obs}}\), but disappears after further inverting \(11\). Every real specialization survives that extra inversion. Thus the same real family admits different arithmetic opens. The construction predicts neither a real parameter nor a physical observable from arithmetic alone; an L-value comparison needs additional structure.
Definition. Enriched rational objects and relative precision [fdip-0041]AGENTDRAFTED
- October 31, 2026
Definition. Enriched rational objects and relative precision [fdip-0041]AGENTDRAFTED
- October 31, 2026
The arithmetic family has both a quadratic form and an operator relative to a specified pairing. To separate the information they retain, an enriched rational object consists of data \[\mathcal B=(V,g_0,q,m^2,V_{\mathrm {ret}},V_{\mathrm {el}}).\] Here \(V\) has dimension \(4\) over \(\mathbb Q\), \(g_0\) is a rational positive definite symmetric pairing, and \(q\) is a rational quadratic form whose half-polar pairing \[b_q(v,w)=\frac {q(v+w)-q(v)-q(w)}2\] is positive definite after extension to \(\mathbb R\). Fix \(m^2\in \mathbb Q_{>0}\) and a \(g_0\)-orthogonal splitting \(V=V_{\mathrm {ret}}\perp V_{\mathrm {el}}\) into two-dimensional summands. This is a rational linear analogue of the supplied pairing, mass and splitting in the enriched background data; no graph realization is assumed. These are additional data, not consequences of \(q\).
The relative precision is the unique operator \(Q:V\to V\) satisfying \[g_0(v,Qw)=b_q(v,w).\] It is the relative operator for these two pairings: rational, \(g_0\)-self-adjoint and positive definite. Define \[\begin {aligned} L_{\mathrm {rel}}&=Q-m^2I,\\ R(\mathcal B)&=\frac {\operatorname {tr}(L_{\mathrm {rel}}^2)} {\bigl (\operatorname {tr}L_{\mathrm {rel}}\bigr )^2}. \end {aligned}\] Restrict these objects to \(L_{\mathrm {rel}}\geq 0\) and \(\operatorname {tr}L_{\mathrm {rel}}\ne 0\). This is the trace ratio on its stated domain. The real Gaussian uses action \(q/2\), the volume induced by \(g_0\), and the normalized law \(\mu _Q\). Neither the factor \(1/2\) in the action nor the reference volume changes the convention \(\iota _q(v)^2=q(v)1\) of the configuration Clifford algebra.
An arrow \(T:\mathcal B\to \mathcal B'\) is a rational linear isomorphism preserving \(g_0,q,m^2\) and carrying each specified summand to its namesake. Preservation of the two pairings gives \(g'_0(Tv,Q'Tw)=g'_0(Tv,TQw)\) for all \(v,w\), whence \[Q'T=TQ,\qquad L'_{\mathrm {rel}}T=TL_{\mathrm {rel}}.\] Trace conjugacy proves \(R(\mathcal B')=R(\mathcal B)\). Identity, inverse and composition preserve these conditions, so the objects and arrows form a groupoid.
Definition. The quadratic center character [fdip-0049]AGENTDRAFTED
- October 31, 2026
Definition. The quadratic center character [fdip-0049]AGENTDRAFTED
- October 31, 2026
Let \(q\) be a nondegenerate rational quadratic form of rank 4,
with half-polar pairing \(b_q\). In particular, forgetting the extra
data of an enriched rational object supplies such a form.
Its
even Clifford algebra has quadratic center
\[E_q=Z(\operatorname {Cl}^+(q))
\simeq \mathbb Q[z]/(z^2-d),\]
where \(d\) represents the signed discriminant class
\(\delta (q)\in \mathbb Q^\times /(\mathbb Q^\times )^2\).
In rank 4 this is the determinant class of \(b_q\).
This uses exactly the field/rank-4 center statement and
proof of the discriminant center, without its
subsequent Spin identifications. For an enriched object, in any common
rational basis,
\[\det (b_q)=\det (g_0)\det (Q).\]
Each pairing determinant changes by a square under a basis
change. Thus \(\det Q\) alone does not supply \(\delta (q)\)
unless the reference-pairing determinant class is also known.
TauCeti's CliffordAlgebra.adjoinRootEquivCenterEven
gives the generic center identification from a nonempty even
orthogonal spanning list of nonisotropic vectors over a field
of characteristic different from two. It supplies this algebraic
step, not the character or trace-observable construction.
Fix an algebraic closure \(\overline {\mathbb Q}\).
The quadratic center character is the Galois character
\[\begin {aligned}
\chi _q:G_{\mathbb Q}&\longrightarrow \{1,-1\},\\
\sigma &\longmapsto \frac {\sigma (\sqrt d)}{\sqrt d},
\end {aligned}\]
where \(G_{\mathbb Q}=\operatorname {Gal}(\overline {\mathbb Q}/\mathbb Q)\).
The value is independent of the sign of the root and of
multiplying \(d\) by a rational square. If \(d\) is a square,
\(E_q\simeq \mathbb Q\times \mathbb Q\) and \(\chi _q\) is trivial.
Otherwise the center is the field \(\mathbb Q(\sqrt d)\) and
\(\chi _q\) is its quadratic character. The corresponding algebraic
dichotomy is formalized by
CliffordAlgebra.nonempty_center_even_algEquiv_prod_iff_isSquare_discriminant
and
CliffordAlgebra.isField_center_even_iff_not_isSquare_discriminant,
with the same field, characteristic and orthogonal-list hypotheses
as the center identification above. The cyclotomic description of the
character is given by Brian Conrad in
[conradQuadraticCharacters, Section 1, p. 1].
The diagram records two constructions on enriched objects. Its left downward arrow is the independently defined trace ratio; no arrow from \(\chi _q\) to \(R\) is asserted. A quadratic isometry induces an even Clifford algebra isomorphism, hence a center isomorphism and the same character.
For a nonsquare class, let \(d_0\) be its squarefree integer
representative and put \(D=d_0\) if \(d_0\equiv 1\pmod 4\),
and \(D=4d_0\) otherwise. The primitive Dirichlet representative
is \(\chi _D(n)=(D/n)\), with Kronecker-symbol convention and
value zero when \(\gcd (n,|D|)>1\); its conductor is \(|D|\).
For the split class use the trivial character of conductor one.
These conventions agree with Brian Conrad's
[conradQuadraticCharacters, Sections 1 and 3, especially Theorem 3.4].
For an integer \(D\) satisfying Int.IsFundamentalDiscr \(D\),
TauCeti's TauCeti.Multiquadratic.fundamentalDiscriminantChar
defines the integer-valued Dirichlet character of level \(|D|\), and
TauCeti.Multiquadratic.isPrimitive_fundamentalDiscriminantChar
proves it primitive, so its conductor is \(|D|\).
These declarations supply this character/conductor step, including \(D=1\).
Fix the uncompleted convention
\[L(s,\chi _D)=\prod _{p\ \mathrm {prime}}
(1-\chi _D(p)p^{-s})^{-1}\]
for \(\operatorname {Re}s>1\), and the comparison point \(s=2\). The product converges absolutely;
no gamma or conductor factor is included. The Euler convention
is Brian Conrad's [conradQuadraticCharacters, p. 5].
The factorization criterion asks whether this
character retains enough information to recover \(R\).
Proposition. Factorization through an invariant requires fiber constancy [fdip-0042]AGENTDRAFTED
- October 30, 2026
Proposition. Factorization through an invariant requires fiber constancy [fdip-0042]AGENTDRAFTED
- October 30, 2026
Let \(X,C,Y\) be sets and let \(c:X\to C\) and \(r:X\to Y\) be functions. There is a function \(F:c(X)\to Y\) with \(r=F\circ c\), viewing \(c\) as a map to its image, if and only if \[c(x)=c(x')\ \Longrightarrow \ r(x)=r(x')\] for all \(x,x'\in X\). When it exists, \(F\) is unique on \(c(X)\). This is the set-level form of the fiber-constancy argument for finite-map pullback; no finiteness is required here.
Proof.
- October 30, 2026
Proof.
- October 30, 2026
If \(r=F\circ c\), equal inputs to \(F\) give equal outputs. Conversely, assign to \(z\in c(X)\) the common value of \(r\) on its nonempty fiber. The condition makes that value well-defined and gives \(F(c(x))=r(x)\). Every element of \(c(X)\) is reached, so this identity also gives uniqueness. This includes the empty image, on which there is exactly one function to \(Y\).
Mathlib's Function.FactorsThrough is the displayed
fiber-constancy condition. Its Function.factorsThrough_iff
extends to the entire codomain \(C\) when \(Y\) is nonempty;
the image formulation above needs no such extra assumption.
Apply this to any set of representatives of the rational enriched objects, first taking \(c(\mathcal B)\) to be the rational quadratic-isometry class of \(q\) and \(r(\mathcal B)=R(\mathcal B)\). Both are unchanged by the declared arrows. A pair of isometric forms with unequal trace ratios excludes every set-level recovery rule from that isometry class on a domain containing the pair. It consequently excludes recovery from any invariant determined solely by that class, including the Clifford algebra's isomorphism class and the quadratic center character \(\chi _q\). In particular, a fixed function of \(L(2,\chi _D)\), or of any fixed collection of values determined solely by the same character, cannot recover \(R\) there. The two rationally isometric fibers provide such a pair.
The criterion asserts neither regularity nor continuity of \(F\). Even fiber constancy would not supply those properties, a choice of a physical observable, or a physical parameter law. The obstruction concerns invariants of \(q\) alone and this independently defined trace ratio. It makes no assertion about arithmetic data that also retain the reference pairing and mass.
Example. Rationally isometric forms with different trace ratios [fdip-0043]AGENTDRAFTED
- October 30, 2026
Example. Rationally isometric forms with different trace ratios [fdip-0043]AGENTDRAFTED
- October 30, 2026
Take the rational alternating four-cycle, with counting pairing \(g_0=I\), fixed \(m^2=1\), and opposite vertices \((0,2)\) retained and \((1,3)\) eliminated. For rational \(t>0\), the eigenvalues of its precision are \[1,\quad 3,\quad 2t+1,\quad 2t+3.\] Thus \(q_t(x)=x^TQ_tx\) is positive, and \(L_{\mathrm {rel}}=Q_t-I\) is the earlier \(L_t\), with nonnegative eigenvalues \(0,2,2t,2t+2\). Its trace is \(4(t+1)>0\). These data lie in the full enriched observable domain.
The arithmetic domain calculation gives \[\begin {aligned} \det Q_t&=3(2t+1)(2t+3),\\ R(t)&=\frac {t^2+t+1}{2(t+1)^2}. \end {aligned}\] Here the determinant is also that of the half-polar pairing, because \(g_0=I\). At the two positive rational parameters, \[\begin {aligned} \det Q_1&=45=5\cdot 3^2,\\ R(1)&=\frac 38,\\ \det Q_{29/2}&=2880=5\cdot 24^2,\\ R(29/2)&=\frac {903}{1922}. \end {aligned}\] For example, at \(t=29/2\) the eigenvalues of \(L_{\mathrm {rel}}\) are \(0,2,29,31\); their sum is \(62\) and the sum of squares is \(1806\). Hence the second ratio is \(1806/62^2=903/1922\). It differs from \(3/8\), since \(8\cdot 903=7224\) and \(3\cdot 1922=5766\).
In fact these forms are rationally isometric. The rational matrix \(H/2\) from Example [fdip-000U] diagonalizes \(Q_t\) by congruence as \(\operatorname {diag}(1,3,2t+1,2t+3)\). The change of basis \[\begin {aligned} P&=\begin {pmatrix}1/2&5/2\\1/2&-3/2\end {pmatrix}, &\det P&=-2,\\ P^T\begin {pmatrix}3&0\\0&5\end {pmatrix}P &=\begin {pmatrix}2&0\\0&30\end {pmatrix} \end {aligned}\] therefore gives \[q_1\simeq \langle 1,3,3,5\rangle \simeq \langle 1,3,2,30\rangle .\] At \(t=29/2\), rescaling the last coordinate by \(1/4\) and then permuting the last two coordinates gives \[\begin {aligned} q_{29/2}&\simeq \langle 1,3,30,32\rangle \\ &\simeq \langle 1,3,30,2\rangle \simeq \langle 1,3,2,30\rangle . \end {aligned}\] All these changes of basis are invertible over \(\mathbb Q\). Thus the fiber-constancy criterion already rules out recovery of \(R\) from the rational isometry class of \(q\).
Both signed discriminant classes are \([5]\). Consequently both even Clifford centers are \(\mathbb Q(\sqrt 5)\), and both have the same quadratic Galois character and the same primitive Dirichlet representative \(\chi _5\), of conductor 5. In the fixed uncompleted convention, the values \(L(2,\chi _5)\) are identical. The fiber-constancy criterion therefore rules out a fixed function of this value recovering \(R\) on this family. The same conclusion holds for any fixed character-only collection of L-values. It uses equality of the character, not a numerical approximation to an L-value.
The loss already occurs when the supplied reference pairing is forgotten. The exhibited quadratic isometry cannot preserve that pairing: if it did, the relative precisions would be conjugate and the trace ratios would agree. Hence no invariant determined solely by the quadratic-isometry class, including an invariant of its Clifford algebra or center, recovers \(R\) on this family. Arithmetic data retaining the reference pairing and mass are not excluded. No physical QFT parameter has been identified with \(R\).
Proposition. Schur elimination multiplies quadratic center characters [fdip-0044]AGENTDRAFTED
- October 30, 2026
Proposition. Schur elimination multiplies quadratic center characters [fdip-0044]AGENTDRAFTED
- October 30, 2026
For an enriched rational object, write its relative precision in the specified orthogonal splitting as \[Q=\begin {pmatrix}A&B\\B^\dagger &C\end {pmatrix}, \qquad S=A-BC^{-1}B^\dagger .\] The positive elimination theorem gives invertible positive \(C,S\). The adjoint uses the restricted reference pairings \(g_{0,\mathrm {ret}},g_{0,\mathrm {el}}\). Define the two rank-two forms \[\begin {aligned} q_S(x)&=g_{0,\mathrm {ret}}(x,Sx),\\ q_C(y)&=g_{0,\mathrm {el}}(y,Cy). \end {aligned}\] Their signed discriminants and associated quadratic Galois characters satisfy \[\delta (q)=\delta (q_S)\delta (q_C),\qquad \chi _q=\chi _{q_S}\chi _{q_C}.\] Multiplication of the \(\{1,-1\}\)-valued characters is their tensor product. It retains the eliminated character as well as the retained one.
Proof.
- October 30, 2026
Proof.
- October 30, 2026
Put \(K=C^{-1}B^\dagger \), as in Theorem [fdip-000D]. The rational triangular isomorphism \(U(x,y)=(x,y+Kx)\) has determinant one. The square-completion identity says \[q(x,y)=q_S(x)+q_C(y+Kx).\] Thus \(q\simeq q_S\perp q_C\) as quadratic forms. In a concatenated rational basis, congruence and \(\det U=1\) give \[\det (b_q)=\det (b_{q_S})\det (b_{q_C}).\] For a rank-two form \(\langle a,b\rangle \), orthogonal Clifford generators \(e_1,e_2\) have squares \(a,b\) and anticommute. Its even algebra has basis \(1,w=e_1e_2\), with \(w^2=-ab\); it is commutative, so it is its own center. Consequently its center is \(\mathbb Q[z]/(z^2+ab)\), and its signed discriminant is \([-ab]\). The dimension formula and this binary algebra are also [elmankarpenkomerkurjev2008quadratic, Section 11, Example 11.2, pp. 57-58].
In rank 4 the signed discriminant has positive determinant sign by the field-center calculation. The two rank-two minus signs therefore cancel, proving the first identity. This is the \(2+2\) instance of [elmankarpenkomerkurjev2008quadratic, Lemma 13.4 and Example 13.5, p. 62]. Choose square roots of representatives \(d_S,d_C\) in \(\overline {\mathbb Q}\). Their product is a square root of \(d_Sd_C\); applying any \(\sigma \in G_{\mathbb Q}\) gives \[\frac {\sigma (\sqrt {d_S}\sqrt {d_C})}{\sqrt {d_S}\sqrt {d_C}} =\frac {\sigma (\sqrt {d_S})}{\sqrt {d_S}} \frac {\sigma (\sqrt {d_C})}{\sqrt {d_C}},\] which proves the character identity, including split classes.
The construction respects the declared arrows. If \(T=T_{\mathrm {ret}}\oplus T_{\mathrm {el}}\) preserves the pairing, action and splitting, the identity \(Q'T=TQ\) gives \[\begin {aligned} C'T_{\mathrm {el}}&=T_{\mathrm {el}}C,\\ B'T_{\mathrm {el}}&=T_{\mathrm {ret}}B,\\ (B')^\dagger T_{\mathrm {ret}}&=T_{\mathrm {el}}B^\dagger . \end {aligned}\] Inversion of the first relation and substitution in the Schur formula yield \(S'T_{\mathrm {ret}}=T_{\mathrm {ret}}S\). The restricted maps consequently preserve \(q_C,q_S\) and both reference pairings. The retained data inherit \(m^2\); they carry no further splitting unless one is supplied. Thus this naturality statement does not make elimination an endofunctor on the already split rank-4 objects. A retained trace ratio uses \(L_{\mathrm {rel,ret}}=S-m^2I\), with the same trace formula.
The lower bound \(S\geq m^2I\) is inherited. Indeed, for \(y_*=-C^{-1}B^\dagger x\), square completion and \(Q\geq m^2I\) give \[\begin {aligned} g_{0,\mathrm {ret}}(x,Sx)&=q(x,y_*)\\ &\geq m^2\bigl (\|x\|^2+\|y_*\|^2\bigr )\\ &\geq m^2\|x\|^2, \end {aligned}\] where the norms use the restricted reference pairings. Thus \(L_{\mathrm {rel,ret}}\geq 0\). Its trace must still be assumed nonzero for the retained ratio to be defined. For example, with counting pairing and the first summand retained, \[Q=\operatorname {diag}(m^2I_2,(m^2+1)I_2)\] has \(\operatorname {tr}(Q-m^2I)=2\), but \(S=m^2I_2\) and \(L_{\mathrm {rel,ret}}=0\). The full trace-ratio domain is therefore not inherited.
The triangular form isometry generally does not preserve \(g_0\). Nor does its graph map \[j_Q(x)=(x,-C^{-1}B^\dagger x)\] preserve the reference pairing: its pulled-back value is \[\begin {aligned} g_0(j_Qx,j_Qx')&=g_{0,\mathrm {ret}}(x,x')\\ &\quad +g_{0,\mathrm {el}}(Kx,Kx'). \end {aligned}\] It is a form isometry \(q(j_Qx)=q_S(x)\) into the full space, not an enriched isomorphism. Clifford functoriality gives an algebra embedding: after square completion it is the inclusion of the Clifford algebra of an orthogonal summand, injective on its monomial basis. But this embedding need not carry even centers into the full even center. In an orthogonal basis adapted to \(q_S\perp q_C\), the retained volume \(e_1e_2\) anticommutes with the even element \(e_1f_1\), where \(f_1\) is an eliminated nonisotropic generator. Both products are nonzero, and characteristic is zero; so this central element of the retained even algebra is not central in the full even algebra.
Primitive Dirichlet representatives must be taken after
multiplying Galois characters. They are not in general the
pointwise product of the zero-extended functions on integers.
At \(t=1\), the cycle Schur computation has
\(\det Q=45\), \(\det S=5\) and \(C=3I_2\). The three signed
square classes are \([5],[-5],[-1]\), with fundamental
discriminants \(5,-20,-4\). The Galois product is \(\chi _5\),
but
\[\chi _{-20}(2)\chi _{-4}(2)=0,\qquad \chi _5(2)=-1.\]
The last value follows from
\(\chi _D(2)=(-1)^{(D^2-1)/8}\) for odd fundamental \(D\),
as in Brian Conrad's [conradQuadraticCharacters, Corollary 3.1, p. 4].
On integers coprime to 20 the product agrees with
\(\chi _5\); passing to its primitive representative restores
the prime-two value. No multiplication rule for the
corresponding L-functions follows from the character law.
Mathlib's DirichletCharacter.primitiveCharacter
and DirichletCharacter.primitiveCharacter_apply_of_isCoprime
separate primitive reduction from evaluation: agreement is
asserted at integers coprime to the original level, which
does not include the prime two in this example.
Remark. The graph half-turn fixes the quadratic center [fdip-0045]AGENTDRAFTED
- October 30, 2026
Remark. The graph half-turn fixes the quadratic center [fdip-0045]AGENTDRAFTED
- October 30, 2026
The alternating-cycle half-turn \(P=(02)(13)\) acts on the rational configuration space, preserving the counting pairing, the action and the opposite-vertex splitting. Its determinant is \(+1\). For every rational \(t>0\), its induced Clifford automorphism fixes the even center pointwise. This action is different from the nontrivial involution of that quadratic algebra.
More generally, let \(q\) be a nondegenerate rational quadratic form of positive even rank \(n\), and let \(T\) be a \(q\)-isometry. Choose a rational orthogonal basis \(e_1,\ldots ,e_n\) and put \(w=\iota _q(e_1)\cdots \iota _q(e_n)\). Then \[\begin {aligned} Z(\operatorname {Cl}^+(q))&=\mathbb Q\cdot 1\oplus \mathbb Q\cdot w,\\ \operatorname {Cl}(T)(w)&=(\det T)w. \end {aligned}\] Thus determinant \(+1\) fixes the center pointwise, while determinant \(-1\) induces its nontrivial involution.
For the center description, use the orthogonal Clifford monomial
basis. A basis monomial in the even algebra commutes with
\(\iota _q(e_i)\iota _q(e_j)\), for \(i\ne j\), precisely when its
index set contains both indices or neither. Every generator square
is nonzero, so these pairs are invertible and their conjugations
act diagonally on that basis. A central linear combination can
therefore involve only the empty and full index sets, since their
membership indicators must agree for every pair. Conversely both
\(1\) and \(w\) commute with every even word. They are independent
because \(n>0\). This gives the stated center and is the general
even-rank center description in TauCeti's
CliffordAlgebra.mem_center_even_iff_exists_eq_add_smul_volume,
under its nonempty even nonisotropic orthogonal spanning-list hypotheses over a
field of characteristic different from two.
For the action, consider the alternating multilinear map \[A(v_1,\ldots ,v_n)=\frac 1{n!} \sum _{\sigma \in S_n}\operatorname {sgn}(\sigma ) \iota _q(v_{\sigma (1)})\cdots \iota _q(v_{\sigma (n)}).\] On an orthogonal list anticommutation makes this its ordered Clifford product. Both \((e_i)\) and \((Te_i)\) are orthogonal, so alternation gives \[\begin {aligned} \operatorname {Cl}(T)(w)&=A(Te_1,\ldots ,Te_n)\\ &=(\det T)A(e_1,\ldots ,e_n)=(\det T)w. \end {aligned}\] Nondegeneracy gives \((\det T)^2=1\). The center is quadratic étale since \(w^2\ne 0\); sending \(w\) to \(-w\) is its unique nontrivial involution. This determinant-action argument is separate from the cited formal center description.
To check the assertion in the actual family, let \(h_1,\ldots ,h_4\) be the columns of the matrix \(H\) in Example [fdip-000U]. They are a rational orthogonal basis for \(q_t\); their nonzero squares are \(4,12,4(2t+1),4(2t+3)\). Direct application of the half-turn gives \[\begin {aligned} Ph_1&=h_1,& Ph_2&=-h_2,\\ Ph_3&=-h_3,& Ph_4&=h_4. \end {aligned}\] The four-dimensional center calculation identifies the center with the span of \(1\) and \[w=\iota _{q_t}(h_1)\iota _{q_t}(h_2) \iota _{q_t}(h_3)\iota _{q_t}(h_4).\] Its image under \(P\) is \((+1)(-1)(-1)(+1)w=w\). Scalars are fixed as well, proving the assertion.
On the same center, the canonical nontrivial algebra involution sends \(w\mapsto -w\). Its square is the identity and it is nontrivial since \(1,w\) are linearly independent. For a field center it is quadratic Galois conjugation; for \(\mathbb Q\times \mathbb Q\) it exchanges the factors. Thus the two-element graph group and the two-element group of center automorphisms have different specified actions: the former acts trivially on the center, whereas the latter acts nontrivially. The center character in Definition [fdip-0049] records the arithmetic Galois action, not this supplied graph symmetry.
Gaussian elimination at every prime [fdip-008M]AGENTDRAFTED
- November 2, 2026
Gaussian elimination at every prime [fdip-008M]AGENTDRAFTED
- November 2, 2026
Which parts of Gaussian elimination depend on continuous quantities? The arithmetic families place the Clifford data over every ring in which \(2\) is a unit, and the bad fibers separate the domains of the form, the elimination, and the trace ratio. The Gaussian law asks a further question. A moment can lie in \(\mathbb Q\) while the constant that normalizes the real density does not.
Take the unit-weight four-cycle with mass squared equal to \(1\). In vertex order \((0,1,2,3)\) its precision is \[Q=\begin {pmatrix}3&-1&0&-1\\-1&3&-1&0\\0&-1&3&-1\\-1&0&-1&3\end {pmatrix},\] so \(\det Q=45\). For these 4 coordinates the real normalizer is \[(2\pi )^{2}(\det Q)^{-1/2},\] as in the finite positive Gaussian normalization. That quantity involves both \(\pi \) and \(\sqrt {45}\). Retain the adjacent vertices \(R=\{0,1\}\) and eliminate \(U=\{2,3\}\). This split is not the opposite-vertex split of the four-cycle elimination. The Schur complement and one moment computed in the next section are \[S=\begin {pmatrix}21/8&-9/8\\-9/8&21/8\end {pmatrix},\qquad \omega _Q(x_2^2x_3x_0+x_2^3x_1)=32/75.\] Both lie in \(\mathbb Q\). In this example the continuous quantity is the real normalizer.
The next section defines the moment rule over a ring and proves that elimination of those moments is the Schur complement, with no real integral. The following section constructs the additive character sum on an odd finite field and its elimination identity. The section after that identifies the Euler product of every nondegenerate integral form with an \(L\)-function of its discriminant character. The last section sums the Epstein zetas of the classes of a negative fundamental discriminant. The Weil index is outside that identity. This chapter does not identify the character sum with the real normalizer.
Theorem. Wick states over a ring [fdip-008N]AGENTDRAFTED
- November 2, 2026
Theorem. Wick states over a ring [fdip-008N]AGENTDRAFTED
- November 2, 2026
Let \(A\) be a commutative ring in which \(2\) is a unit, and let \(Q\) be a symmetric \(n\times n\) matrix over \(A\) with an inverse \(C=Q^{-1}\) in \(M_n(A)\). Write \(A[x]=A[x_1,\ldots ,x_n]\). The Wick functional \(\omega _Q\) is the \(A\)-linear map \(A[x]\to A\) with \(\omega _Q(1)=1\) determined by Isserlis' pairing rule. On a product of an odd number of factors the value is \(0\). On a product of \(2m\) factors, not necessarily distinct, sum over the pairings of those \(2m\) factor positions the product of the \(m\) entries of \(C\) on the paired positions. There are \((2m-1)!!\) such pairings, so \(\omega _Q(x_i^4)=3C_{ii}^2\). The value depends only on those entries. It uses no order on \(A\) and no measure on \(A^n\). The same pairing rule is the one applied to centered real Gaussians in the quartic elimination, which cites [etingof2024mathematical, v2, Theorem 3.1 and Example 3.2, p. 29] for these contractions. Here the rule is the definition of \(\omega _Q\).
Order the coordinates as a retained set \(R\) and an eliminated set \(U\), and assume that the block \(Q_{UU}\) is invertible over \(A\). Define \[\begin {aligned} L&=Q_{UU}^{-1}Q_{UR},\\ B&=-L,\\ S&=Q_{RR}-Q_{RU}L. \end {aligned}\] Symmetry of \(Q\) makes \(S\) symmetric. For \(f\in A[x]\), substitute \(x_U=Bx_R+z\) and apply the Wick functional of covariance \(Q_{UU}^{-1}\) in the indeterminates \(z\), treating the retained variables as coefficients. Call the result \(E[f\mid x_R]\in A[x_R]\).
The block \(S\) is invertible, and \(C_{RR}=S^{-1}\). Restriction of \(\omega _Q\) to \(A[x_R]\) is the Wick functional \(\omega _S\). Furthermore \(E[f\mid x_R]\) is a polynomial and \[\omega _Q(f)=\omega _S(E[f\mid x_R]).\] The identity \(2^{-1}x^TQx=2^{-1}z^TQ_{UU}z+2^{-1}x_R^TSx_R\), with \(z=x_U-Bx_R\), is the quadratic completion that names these blocks. The moment proof does not integrate that quadratic.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Factor the symmetric matrix in retained and eliminated blocks as \[\begin {aligned} Q&=\begin {pmatrix}I&Q_{RU}Q_{UU}^{-1}\\0&I\end {pmatrix} \begin {pmatrix}S&0\\0&Q_{UU}\end {pmatrix} \begin {pmatrix}I&0\\L&I\end {pmatrix}. \end {aligned}\] The two outer factors are invertible over \(A\): each is undone by changing the sign of its off-diagonal block. The hypothesis already makes \(Q_{UU}\) invertible. If \(S\) is invertible, the block-diagonal matrix of \(S^{-1}\) and \(Q_{UU}^{-1}\) inverts the middle factor, so that factor and \(Q\) are invertible. Conversely, if \(Q\) is invertible then the middle factor \(D\) is invertible. If \(DE=I=ED\), the retained block of \(DE\) is \(S\) times the retained block of \(E\), and the retained block of \(ED\) is that block times \(S\). Both products are the identity, so \(S\) is invertible. The same reading applies to \(Q_{UU}\). Thus, once \(Q_{UU}\) is invertible, \(Q\) is invertible if and only if \(S\) is. The running hypotheses give both, so \(S\) is invertible. The inverse is \[\begin {aligned} C&=\begin {pmatrix}I&0\\-L&I\end {pmatrix} \begin {pmatrix}S^{-1}&0\\0&Q_{UU}^{-1}\end {pmatrix} \begin {pmatrix}I&-Q_{RU}Q_{UU}^{-1}\\0&I\end {pmatrix}. \end {aligned}\] Reading blocks gives \(C_{RR}=S^{-1}\) and \(C_{UR}=-LS^{-1}\). A polynomial in the retained variables alone is paired only on retained indices, so its value under \(\omega _Q\) uses only \(C_{RR}\). That is \(\omega _S\).
The same inverse gives \[C_{UU}=Q_{UU}^{-1}+LS^{-1}Q_{RU}Q_{UU}^{-1}.\] Symmetry makes \(Q_{RU}Q_{UU}^{-1}=L^T\). For the linear forms \(z=x_U+Lx_R\), the cross covariance is \[C(z,x_R)=C_{UR}+LC_{RR}=-LS^{-1}+LS^{-1}=0.\] The unshifted cross blocks are \[C_{RU}=-S^{-1}L^T,\qquad C_{UR}=-LS^{-1}.\] Expanding the residual in those blocks gives \[\begin {aligned} C(z,z)&=C_{UU}+LC_{RR}L^T+LC_{RU}+C_{UR}L^T\\ &=Q_{UU}^{-1}+LS^{-1}L^T+LS^{-1}L^T\\ &\qquad +L(-S^{-1}L^T)+(-LS^{-1})L^T\\ &=Q_{UU}^{-1}. \end {aligned}\] Thus, under \(\omega _Q\), the linear forms \((x_R,z)\) have covariance \(\operatorname {diag}(S^{-1},Q_{UU}^{-1})\).
If \(\ell =a^Tx\) and \(\ell '=b^Tx\), the pairing rule gives \(\omega _Q(\ell \ell ')=a^TCb\). By multilinearity the same holds for a product of linear forms: its moment is the Isserlis value of the matrix of those pairwise covariances. Since \(x_U=z-Lx_R\), one has \(f(x)=f(x_R,Bx_R+z)\) as polynomials. The moment \(\omega _Q(f)\) is therefore the Isserlis moment of \((x_R,z)\) at the block diagonal covariance above. A matching that joins a retained factor to a residual factor contributes \(0\). Every surviving matching is a retained matching times a residual matching, and the sum factors. Averaging the residual variables first, with coefficients in \(A[x_R]\), is \(E[f\mid x_R]\). The retained Wick functional of that polynomial is \(\omega _Q(f)\).
For the quadratic completion expand \(x_U=z+Bx_R=z-Lx_R\). The cross term produced by \(Q_{UR}\) cancels against \(Q_{UU}L\), and the retained square that remains is \(S\). Each half is legitimate because \(2\) is a unit. This is the same block arithmetic as the real elimination theorem, without positivity and without the factor \((2\pi )^{|U|/2}(\det Q_{UU})^{-1/2}\).
The correspondence with formal libraries is partial. Mathlib's
Matrix.fromBlocks_eq_of_invertible₂₂ is the block
factorization over a commutative ring, and
Matrix.isUnit_fromBlocks_iff_of_invertible₂₂ is the criterion
that, once the eliminated block is invertible, the matrix is a unit if
and only if the Schur complement is. Matrix.det_fromBlocks₂₂
is the determinant identity. No Mathlib or TauCeti declaration supplies
the Isserlis pairing rule or the tower identity over a commutative ring.
TauCeti's Matrix.PosDef.gaussianCondCov is the real
positive-definite case only, as already recorded for the
real elimination theorem.
On the four-cycle matrix of the chapter, \(Q_{UU}=\begin {pmatrix}3&-1\\-1&3\end {pmatrix}\) has determinant \(8\), and \[B=\frac 18\begin {pmatrix}1&3\\3&1\end {pmatrix},\qquad \det S=45/8.\] The product of the determinants is \(\det Q_{UU}\cdot \det S=45=\det Q\). Take \(f=x_2^2x_3x_0+x_2^3x_1\). Exact rational evaluation of the two Wick functionals gives \(\omega _Q(f)=\omega _S(E[f\mid x_R])=32/75\). The conditional expectation lies in \(\mathbb Q[x_0,x_1]\).
The rule is not the odd Wick rule, whose matrix is alternating and whose value is a Pfaffian. It defines no measure on \(A^n\), no finite-field character sum, and no Euler product. Characteristic \(2\) is outside the hypothesis; the half-turn example is the place where an algebra in that characteristic is treated. Nothing here evaluates the real normalizer or compares these moments with the logarithm of a determinant.
Theorem. Finite-field partition functions [fdip-008O]AGENTDRAFTED
- November 2, 2026
Theorem. Finite-field partition functions [fdip-008O]AGENTDRAFTED
- November 2, 2026
What takes the place of a Gaussian partition function when field values lie in a finite field? Let \(p\) be an odd prime and let \(e(t)=\exp (2\pi i t/p)\) for the representative of \(t\in \mathbb F_p\) in \(\{0,\ldots ,p-1\}\). For a symmetric \(n\times n\) matrix \(Q\) over \(\mathbb F_p\), define \[Z_p(Q)=\sum _{x\in \mathbb F_p^n}e(x^TQx).\] The exponent is the full quadratic form \(x^TQx\), not half of it. The sum is a complex number. It is not a probability.
Write \(\bigl (\frac {a}{p}\bigr )\) for the Legendre symbol, and \[g=\sum _{t\in \mathbb F_p}e(t^2).\] If \(\det Q\neq 0\) in \(\mathbb F_p\), then \[Z_p(Q)=\Bigl (\frac {\det Q}{p}\Bigr )g^n,\qquad g^2=\Bigl (\frac {-1}{p}\Bigr )p.\] In particular, when \(n\) is divisible by \(4\), \[Z_p(Q)=\Bigl (\frac {\det Q}{p}\Bigr )p^{n/2},\] an ordinary integer. If a coordinate split has \(Q_{UU}\) invertible, with Schur complement \(S\) and \(B=-Q_{UU}^{-1}Q_{UR}\) as in the Wick state, then for every retained vector \[\sum _{x_U}e(x^TQx)=Z_p(Q_{UU})\,e(x_R^TSx_R).\] The same block factorization gives \(\det Q=\det Q_{UU}\det S\), so the Legendre symbol of the determinant factors as a product.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
For \(a\in \mathbb F_p\), put \(g(a)=\sum _te(at^2)\). Then \(g(0)=p\). The value \(g(a)\) depends only on the square class of \(a\): if \(a=c^2b\) with \(c\neq 0\), the substitution \(t=c^{-1}s\) gives \(g(a)=g(b)\). There are \((p-1)/2\) nonzero squares and the same number of nonsquares. Summing the nontrivial additive character, \[\sum _{a\neq 0}g(a)=\sum _t\sum _{a\neq 0}e(at^2)=(p-1)+(p-1)(-1)=0,\] because the inner sum is \(p-1\) at \(t=0\) and \(-1\) for \(t\neq 0\). Hence \(g(\nu )=-g\) for any nonsquare \(\nu \), which is \(g(a)=\bigl (\frac {a}{p}\bigr )g\) for \(a\neq 0\).
The change of variables \(u=x-y\), \(v=x+y\) is bijective on \(\mathbb F_p^2\) because \(2\) is invertible: \(x=2^{-1}(u+v)\) and \(y=2^{-1}(v-u)\). It turns the difference of squares into a product, so \[\sum _{x,y}e(x^2-y^2)=\sum _{u,v}e(uv)=p.\] The left side is \(g\cdot g(-1)=\bigl (\frac {-1}{p}\bigr )g^2\). Therefore \(g^2=\bigl (\frac {-1}{p}\bigr )p\).
Over a field of characteristic not \(2\), a symmetric matrix is congruent to a diagonal matrix. If \(Q=0\) it is already diagonal. Otherwise some quadratic value is nonzero: if every \(v^TQv\) vanished, the polarization identity \[(x+y)^TQ(x+y)-x^TQx-y^TQy=2x^TQy\] would force every bilinear value to vanish, hence \(Q=0\). Take such a vector first in a basis, and replace each later basis vector \(w\) by \(w-(v^TQw)(v^TQv)^{-1}v\). The change is invertible, those vectors are orthogonal to \(v\), and the form splits off the line through \(v\). Induction diagonalizes the complement.
If \(A\) is invertible and \(R=A^TQA\), then \(y=A^{-1}x\) runs through \(\mathbb F_p^n\) as \(x\) does, and \(x^TQx=y^TRy\). Thus \(Z_p(Q)=Z_p(R)\). Also \(\det R=(\det A)^2\det Q\), so the two matrices have the same Legendre symbol. On a nondegenerate diagonal matrix \(\operatorname {diag}(a_1,\ldots ,a_n)\) the sum factors as \(\prod _ig(a_i)=\bigl (\frac {\det R}{p}\bigr )g^n\). This is the stated formula. When \(4\) divides \(n\), the exponent \(n/2\) is even, so \[g^n=(g^2)^{n/2}=\Bigl (\frac {-1}{p}\Bigr )^{n/2}p^{n/2}=p^{n/2}.\]
For the elimination, set \(z=x_U-Bx_R\). As \(x_U\) runs through the eliminated space, so does \(z\). Expanding the symmetric form gives the polynomial identity \[x^TQx=z^TQ_{UU}z+x_R^TSx_R,\] the same cancellation used for the quadratic completion in the Wick state, applied to the full form rather than to half of it. Additivity of \(e\) factors the sum.
Write \(Q\) in retained and eliminated blocks and factor it as in the Wick state, with unitriangular factors of determinant \(1\) and a block-diagonal factor \(\operatorname {diag}(S,Q_{UU})\). The determinant multiplies, so \(\det Q=\det Q_{UU}\det S\).
The identity \(\det Q=\det Q_{UU}\det S\) is the finite-field form of the block factorization used for the quadratic center characters. It does not prove that rational character identity.
For a symmetric \(n\times n\) matrix over \(\mathbb F_p\), define the signed discriminant \(d_{\pm }(Q)=(-1)^{\frac {n(n-1)}{2}}\det Q\) in \(\mathbb F_p\). If \(\det Q\neq 0\), then \[Z_p(Q)=\Bigl (\frac {d_{\pm }(Q)}{p}\Bigr )g^{\varepsilon }p^{m},\] where \(n=2m+\varepsilon \) and \(\varepsilon \) is \(0\) or \(1\). When \(4\) divides \(n\), one has \(\varepsilon =0\) and \(d_{\pm }(Q)=\det Q\), so this is the power stated above.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The nondegenerate evaluation gives \(Z_p(Q)=\bigl (\frac {\det Q}{p}\bigr )g^n\), and \(g^2=\bigl (\frac {-1}{p}\bigr )p\). Hence \(g^n=g^{\varepsilon }(g^2)^m =g^{\varepsilon }\bigl (\frac {-1}{p}\bigr )^m p^m\), and \[Z_p(Q)=\Bigl (\frac {(-1)^m\det Q}{p}\Bigr )g^{\varepsilon }p^{m}.\] The exponent \(m\) has the same parity as \(\frac {n(n-1)}{2}\). If \(\varepsilon =0\), then \(n=2m\) and \(\frac {n(n-1)}{2}=m(2m-1)\); the factor \(2m-1\) is odd. If \(\varepsilon =1\), then \(n=2m+1\) and \(\frac {n(n-1)}{2}=m(2m+1)\); the factor \(2m+1\) is odd. In both cases \((-1)^m=(-1)^{\frac {n(n-1)}{2}}\), so the symbol is that of \(d_{\pm }(Q)\). When \(4\) divides \(n\), the integer \(m\) is even, and the sign is \(+1\).
Now suppose \(\det Q=0\), and let \(r\) be the rank of \(Q\). The same diagonalization, which does not require a nonzero determinant, produces an invertible change of variables to \(\operatorname {diag}(a_1,\ldots ,a_r,0,\ldots ,0)\) with every \(a_i\neq 0\). In the new coordinates the last \(n-r\) basis vectors span the kernel. Then \[Z_p(Q)=p^{n-r}Z_p(Q'),\] where \(Q'=\operatorname {diag}(a_1,\ldots ,a_r)\). If \(r=0\), the original form is zero and \(Z_p(Q)=p^n\). If \(r\ge 1\), the signed evaluation on \(Q'\) gives \[Z_p(Q)=p^{n-r}\Bigl (\frac {d_{\pm }(Q')}{p}\Bigr )g^{\varepsilon '}p^{m'},\] with \(r=2m'+\varepsilon '\) and \(\varepsilon '\) equal to \(0\) or \(1\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The diagonalization already proved for a form that is not identically zero splits off a line whenever some quadratic value is nonzero, and it stops when every remaining value is zero. On that diagonal matrix the equation \(Qv=0\) reads \(a_iv_i=0\) for each \(i\le r\), so those coefficients vanish and the zero block is the kernel. An invertible change of variables preserves the partition function, by the same substitution used in the nondegenerate case. On the diagonal matrix the sum factors as a product of one-variable sums. Each nonzero entry \(a_i\) contributes \(g(a_i)\), and each zero entry contributes \(\sum _te(0)=p\). There are \(n-r\) zero entries, so the power of \(p\) is \(p^{n-r}\), and the product of the \(g(a_i)\) is \(Z_p(Q')\). The nondegenerate evaluation and the signed formula apply to \(Q'\).
The symbol \(\bigl (\frac {d_{\pm }(Q')}{p}\bigr )\) does not depend on the choice of splitting. Another invertible substitution multiplies \(\prod _ia_i\) by a square, so it preserves the Legendre symbol of that product. The sign \(\,(-1)^{\frac {r(r-1)}{2}}\) depends only on the rank, and the rank is unchanged by an invertible substitution. If \(r=0\), there is no diagonal product: every one of the \(p^n\) vectors contributes \(e(0)=1\).
Suppose a coordinate split has \(Q_{UU}\) invertible, with Schur complement \(S\), and write \(n_U\) and \(n_R\) for the two block sizes. Then \(Z_p(Q)=Z_p(Q_{UU})Z_p(S)\), and \(d_{\pm }(Q)=(-1)^{n_Un_R}d_{\pm }(Q_{UU})d_{\pm }(S)\). The sign is \(+1\) when \(n_U\) or \(n_R\) is even.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Summing the elimination identity over the retained vectors multiplies the two partition functions. For the signed discriminants, the exponent identity \[\frac {n(n-1)}{2} =\frac {n_U(n_U-1)}{2}+\frac {n_R(n_R-1)}{2}+n_Un_R\] holds for \(n=n_U+n_R\), and the block factorization gives \(\det Q=\det Q_{UU}\det S\). Multiplying the signs produces the factor \((-1)^{n_Un_R}\).
On the massive four-cycle, \(n=4\) and \(\det Q=45\), so \(d_{\pm }(Q)=\det Q\), because the exponent \(\frac {4\cdot 3}{2}\) equals \(6\). For an odd prime that does not divide \(45\), \(Z_p(Q)=\bigl (\frac {45}{p}\bigr )p^2\). Since \(45=9\cdot 5\) and \(9\) is a square, \(\bigl (\frac {9}{p}\bigr )=1\), and the value equals \(\bigl (\frac {5}{p}\bigr )p^2\).
Characteristic \(2\) is outside the argument, because both the polarization step and the change of variables divide by \(2\). The kernel dimension \(n-r\) records the rank drop of \(Q\) itself. Different domains separate the primes at which a chosen elimination block stays invertible from the primes at which a trace ratio stays regular; those loci are not this kernel. This section gives no Euler product and no comparison with the real normalizer.
Theorem. The Euler product [fdip-008P]AGENTDRAFTED
- November 2, 2026
Theorem. The Euler product [fdip-008P]AGENTDRAFTED
- November 2, 2026
The finite-field partition functions attach one complex number \(Z_p(Q)\) to a symmetric integral matrix at each odd prime. For a nondegenerate form that number is a signed Legendre symbol times an explicit normaliser. The product of those normalised factors is an \(L\)-function of the discriminant character.
Let \(Q\) be a symmetric \(n\times n\) integral matrix with \(\det Q\neq 0\). Write \(d_{\pm }(Q)\) for its signed discriminant, the integer \((-1)^{n(n-1)/2}\det Q\) named by the finite-field evaluation, and let \(\chi _D\) be the primitive character of that integer in the discriminant note. When \(d_{\pm }(Q)\) is a square, this character is the trivial character of conductor one; write \(D=1\) in that case. For an odd prime \(p\) that does not divide \(\det Q\), the signed evaluation gives \[Z_p(Q)=\Bigl (\frac {d_{\pm }(Q)}{p}\Bigr )g^{\varepsilon }p^{m},\] where \(n=2m+\varepsilon \) and \(\varepsilon \) is \(0\) or \(1\). The Gauss sum satisfies \(g^2=\bigl (\frac {-1}{p}\bigr )p\neq 0\), so the quotient \(\hat Z_p(Q)=\frac {Z_p(Q)}{g^{\varepsilon }p^{m}}\) equals \(\bigl (\frac {d_{\pm }(Q)}{p}\bigr )\). For \(\operatorname {Re}s>1\), \[\prod _{p\nmid 2\det Q}\bigl (1-\hat Z_p(Q)\,p^{-s}\bigr )^{-1} =L(s,\chi _D) \prod _{p\mid 2\det Q,\ p\nmid D} \bigl (1-\chi _D(p)\,p^{-s}\bigr ).\] No prime divides \(D=1\), so in the square case the second product runs over every prime dividing \(2\det Q\). The comparison point with the quadratic center character is \(s=2\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The signed evaluation is the identity quoted above, and the quotient by \(g^{\varepsilon }p^{m}\) is the displayed Legendre symbol. That symbol equals \(\pm 1\). A prime in the left-hand product does not divide \(2\det Q\), so it is odd and does not divide \(d_{\pm }(Q)\). The discriminant note therefore gives \(\bigl (\frac {d_{\pm }(Q)}{p}\bigr )=\chi _D(p)\), and \(\hat Z_p(Q)=\chi _D(p)\) at every such prime.
The uncompleted product \(L(s,\chi _D)=\prod _p\bigl (1-\chi _D(p)p^{-s}\bigr )^{-1}\) is the one fixed in the center note, absolutely convergent for \(\operatorname {Re}s>1\). For \(\operatorname {Re}s>1\) every factor \(1-\chi _D(p)p^{-s}\) is nonzero. The left-hand product is that product with the finitely many primes dividing \(2\det Q\) removed, so it equals \(L(s,\chi _D)\) divided by \(\prod _{p\mid 2\det Q}\bigl (1-\chi _D(p)p^{-s}\bigr )^{-1}\). Division by an inverted factor is multiplication by the factor itself. At a prime dividing \(D\), \(\chi _D(p)=0\), so \(1-\chi _D(p)p^{-s}=1\) and that prime drops out. The quotient is therefore \(L(s,\chi _D)\) times \(\prod _{p\mid 2\det Q,\ p\nmid D}\bigl (1-\chi _D(p)\,p^{-s}\bigr )\), which is the right-hand side. Both sides are equal as convergent products, not as a truncation.
When \(n\) is odd, \(\varepsilon =1\), and the normaliser retains one factor \(g\). The sign \(\,(-1)^m\) already sits inside the Legendre symbol, so \(\hat Z_p(Q)\) is that real symbol. This section does not choose a square root of \(p\), and it does not replace \(g\) by a complex unit.
The product omits \(2\) and every prime divisor of \(\det Q\). At an odd prime where the rank of \(Q\) drops to \(r\), the same finite-field note gives \(Z_p(Q)=p^{n-r}Z_p(Q')\) for a nondegenerate block \(Q'\) of rank \(r\), and \(p^n\) when \(r=0\). That value is not the quotient by the nondegenerate normaliser of rank \(n\). The prime \(2\) lies outside because the diagonalization divides by \(2\).
On the massive four-cycle, \(n=4\) and \(d_{\pm }(Q)=45\). Since \(45=9\cdot 5\) and \(5\equiv 1\pmod 4\), the discriminant of that integer is \(D=5\). The omitted primes that do not divide \(5\) are \(2\) and \(3\). Under the Kronecker convention named in the center note, \(\chi _5(2)=\bigl (\frac {5}{2}\bigr )=(-1)^{(5^2-1)/8}=-1\). Since \(5\equiv 2\pmod 3\) and \(2^{(3-1)/2}\equiv -1\pmod 3\), \(\bigl (\frac {5}{3}\bigr )=-1\). The character note gives \(\chi _5(3)=\bigl (\frac {5}{3}\bigr )\). The prime \(5\) divides \(D\), so \(\chi _5(5)=0\) and that factor is not restored. The identity specialises to \[L(s,\chi _5)\,(1+2^{-s})\,(1+3^{-s}).\] At \(s=2\) the two restored factors are \(5/4\) and \(10/9\).
The correspondence with formal libraries is partial. Mathlib's
legendreSym.quadratic_reciprocity is the law that exchanges
the two arguments of a Legendre symbol. This section does not use that
law. Mathlib's DirichletCharacter.LFunction agrees, for real
part greater than \(1\), with the Dirichlet series
\(\sum _n\chi (n)n^{-s}\). Neither declaration identifies
\(\hat Z_p(Q)\) with \(\chi _D(p)\) or assembles the product above.
The identity does not evaluate \(L(s,\chi _D)\) in closed form. In particular it does not derive \(4\pi ^2/(25\sqrt 5)\).
A function of \(L(s,\chi _D)\) does not recover a trace ratio. That obstruction is the fiber-constancy criterion, which concerns invariants of the quadratic form alone. The product above does not evaluate a Weil index, and it is not identified with the real normalizer.
Theorem. The discriminant character of an integer [fdip-00A5]AGENTDRAFTED
- November 2, 2026
Theorem. The discriminant character of an integer [fdip-00A5]AGENTDRAFTED
- November 2, 2026
The quadratic center character attaches to a square class its primitive Dirichlet character. A partition function produces Legendre symbols of one integer. This note identifies the two on odd primes.
Let \(d\) be a nonzero integer. If \(d\) is a square, the center note uses the trivial character of conductor one. If \(d\) is not a square, let \(d_0\) be its squarefree integer representative, with the sign of \(d\), and set \(D=d_0\) when \(d_0\equiv 1\pmod 4\) and \(D=4d_0\) otherwise. Write \(\chi _D\) for the primitive character of that discriminant in the center note. For an odd prime \(p\) that does not divide \(d\), \(\bigl (\frac {d}{p}\bigr )=\chi _D(p)\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
For an odd prime \(p\) and an integer \(a\) not divisible by \(p\), the symbol \(\bigl (\frac {a}{p}\bigr )\) is \(1\) when \(a\) is a nonzero square modulo \(p\), and \(-1\) otherwise. The group \(\mathbb F_p^\times \) has \((p-1)/2\) squares. The equation \(x^2=1\) factors as \((x-1)(x+1)=0\), so the kernel of the squaring map is the two units \(1\) and \(-1\). In that field, every square \(a=b^2\) satisfies \(a^{(p-1)/2}=b^{p-1}=1\). The polynomial \(X^{(p-1)/2}-1\) has at most \((p-1)/2\) roots, so the squares are all of its roots. A nonsquare is not among them. Fermat's identity \(a^{p-1}-1=0\) factors as \((a^{(p-1)/2}-1)(a^{(p-1)/2}+1)=0\), so a nonsquare satisfies \(a^{(p-1)/2}=-1\) in the field. Thus there is a unique residue \(\varepsilon \) among \(1\) and \(-1\) such that \(a^{(p-1)/2}\equiv \varepsilon \pmod p\), and \(\varepsilon \) is the symbol just defined. The integer power itself need not lie in that pair.
The symbol is multiplicative. If \(p\) divides neither \(a\) nor \(b\), the field powers satisfy \[(ab)^{(p-1)/2}\equiv a^{(p-1)/2}b^{(p-1)/2}\pmod p.\] Each of those three powers is congruent to its symbol, so \[\bigl (\frac {ab}{p}\bigr )\equiv \bigl (\frac {a}{p}\bigr )\bigl (\frac {b}{p}\bigr )\pmod p.\] Both sides lie among \(1\) and \(-1\). Those two residues are distinct modulo an odd prime, so the two sides are equal as integers. A square \(c^2\) not divisible by \(p\) therefore has symbol \(1\).
Every nonzero integer has a unique squarefree kernel. Factor \(d=\varepsilon \prod _pp^{a_p}\), with \(\varepsilon \) the sign of \(d\) and each \(a_p\ge 0\). Let \(d_0\) be \(\varepsilon \) times the product of the primes whose exponent is odd, and let \(f^2\) absorb every even part of an exponent. Then \(d=f^2d_0\). No square \(p^2\) divides \(d_0\). The sign is unique, and so is the set of primes of odd exponent, so \(d_0\) is unique.
The odd prime \(p\) does not divide \(d\), so it divides neither \(f\) nor \(d_0\). Multiplicativity gives \(\bigl (\frac {d}{p}\bigr )=\bigl (\frac {d_0}{p}\bigr )\). The center note writes \(\chi _D(n)=\bigl (\frac {D}{n}\bigr )\) under its Kronecker convention, and that value is \(0\) when \(p\) divides \(D\). On an odd prime that does not divide \(D\), this note reads \(\bigl (\frac {D}{p}\bigr )\) as the Legendre symbol just defined. The prime \(2\) is not given that reading. If \(d\) is a square, that note uses the trivial character, and the symbol just proved is \(1\). If \(d\) is not a square and \(d_0\equiv 1\pmod 4\), then \(D=d_0\). The prime \(p\) does not divide \(D\), so \(\chi _D(p)=\bigl (\frac {d_0}{p}\bigr )\). If instead \(D=4d_0\), the same prime is odd and does not divide \(d_0\), so it does not divide \(D\). Then \(\bigl (\frac {D}{p}\bigr )=\bigl (\frac {4}{p}\bigr )\bigl (\frac {d_0}{p}\bigr )\), and \(4\) is a square, so the first factor is \(1\). In every case \(\bigl (\frac {d}{p}\bigr )=\chi _D(p)\).
The center note records that \(\chi _D\) is primitive of conductor \(|D|\). This section uses that conductor and does not re-prove it. The identification is the equality of symbols on odd primes. It is not the law that exchanges the two arguments of a Legendre symbol.
Theorem. Class Epstein zetas sum to a Dirichlet value [fdip-008Q]AGENTDRAFTED
- November 2, 2026
Theorem. Class Epstein zetas sum to a Dirichlet value [fdip-008Q]AGENTDRAFTED
- November 2, 2026
The preceding section identifies a local factor with the discriminant character. The same character has a global sum over classes of binary forms. Let \(D<0\) be a fundamental discriminant: either \(D\equiv 1\pmod 4\) and \(D\) is squarefree, or \(D=4m\) with \(m\) squarefree and \(m\equiv 2\pmod 4\) or \(m\equiv 3\pmod 4\). A positive definite binary form of discriminant \(D\) is \(Q(x,y)=ax^2+bxy+cy^2\) with \(a>0\) and \(b^2-4ac=D\). Two such forms are equivalent when one is the other after an \(\mathrm {SL}_2(\mathbb Z)\) change of variables. Equivalent forms represent the same integers equally often, because the change of variables is a bijection of \(\mathbb Z^2\).
For \(\operatorname {Re}s>1\) the Epstein zeta of \(Q\) is \[E_Q(s)=\sum _{(x,y)\neq (0,0)}Q(x,y)^{-s}.\] Let \(\chi _D\) be the quadratic center character of \(D\). It is completely multiplicative, it vanishes when \(\gcd (n,|D|)>1\), and on an odd prime it is the Legendre symbol of Theorem [fdip-00A5]. The prime \(2\) is not given that reading. When \(D\) is even, \(\chi _D(2)=0\) because \(\gcd (2,|D|)>1\), which is the vanishing clause of the center note. When \(D\) is an odd fundamental discriminant, the value already stated in Proposition [fdip-0044] is \(\chi _D(2)=(-1)^{(D^2-1)/8}\), from [conradQuadraticCharacters, Corollary 3.1, p. 4]. That sign is \(1\) when \(D\equiv 1\pmod 8\) and \(-1\) when \(D\equiv 5\pmod 8\). This is the value of the symbol in the Euler factor \((1-\chi _D(2)\,2^{-s})^{-1}\) of the center note. Let \(w_D\) be the number of integer solutions of \(t^2-Du^2=4\). Write \(\zeta (s)=\sum _{n\ge 1}n^{-s}\) and write \(L(s,\chi _D)\) for the Euler product in the center note. Let \(\mathcal F\) contain one form from each equivalence class.
Then \[\sum _{Q\in \mathcal F}E_Q(s)=w_D\,\zeta (s)\,L(s,\chi _D).\] The weight is \(w_D=6\) when \(D=-3\), \(w_D=4\) when \(D=-4\), and \(w_D=2\) otherwise. For \(D=-4\) the only class is \(x^2+y^2\), so that one zeta equals \(4\zeta (s)L(s,\chi _{-4})\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Since \(D<0\), the equation \(t^2+|D|u^2=4\) forces \(|u|\le 1\). The solutions with \(u=0\) are \((t,u)=(\pm 2,0)\). When \(|u|=1\), \(t^2=4-|D|\), so \(t=\pm 1\) when \(|D|=3\) and \(t=0\) when \(|D|=4\). Thus \(|D|=3\) gives 6 solutions, \(|D|=4\) gives 4, and every larger value gives two. These are the three values of \(w_D\).
The matrix of \(Q\) has determinant \(-D/4\) up to the usual factor \(4\). Explicitly, \[\det \begin {pmatrix}2a&b\\b&2c\end {pmatrix}=-D.\] An element \(\gamma \in \mathrm {SL}_2(\mathbb Z)\) replaces that matrix by a congruent matrix, so it preserves \(D\). Let \(\tau =(-b+\sqrt {D})/(2a)\) be the root in the upper half plane, taking the square root of positive imaginary part. The factorization \(Q(x,y)=a(x-\tau y)(x-\overline {\tau } y)\) shows that an automorph permutes the two roots. Determinant \(1\) preserves the upper half plane, so the automorph fixes \(\tau \). If \(\gamma =\begin {pmatrix}p&q\\r&s\end {pmatrix}\), the fixed-point equation is \(r\tau ^2+(s-p)\tau -q=0\). The minimal equation \(a\tau ^2+b\tau +c=0\) is irreducible over \(\mathbb Q\), so there is a rational scalar \(u\) with \(r=au\), \(s-p=bu\), and \(q=-cu\). First, \(\gcd (a,b,c)=1\). A prime dividing all three coefficients square-divides \(D\). The odd part of a fundamental discriminant is squarefree, so that prime is not odd. If the prime is \(2\), then \(D=4m\). Writing the coefficients as twice integers \(a'\), \(b'\), and \(c'\) gives \(m=b'^2-4a'c'\equiv b'^2\pmod 4\), and a square modulo \(4\) is \(0\) or \(1\), contrary to the fundamental condition on \(m\). Bézout's identity therefore writes \(1\) as an integer combination of \(a\), \(b\), and \(c\), and the rational scalar \(u\) is an integer. Set \(t=p+s\). The determinant \(ps-qr=1\) becomes \((t^2-Du^2)/4=1\). Conversely each solution \((t,u)\) determines \[p=\frac {t-bu}{2},\qquad s=\frac {t+bu}{2},\qquad q=-cu,\qquad r=au.\] The same parity of \(t\) and \(bu\) makes \(p\) and \(s\) integers, since \(t^2\equiv Du^2\pmod 2\) and \(D\equiv b^2\pmod 2\). The form produced by \(\gamma \) has the same root and the same discriminant, so it is a positive multiple of \(Q\). The discriminant scales by the square of that multiple, and the multiple is positive, so the multiple is \(1\). Thus these \(w_D\) matrices are exactly the automorphs of every form of discriminant \(D\).
Let \(R(n)\) be the number of pairs \(\bigl (Q,(x,y)\bigr )\) with \(Q\in \mathcal F\) and \(Q(x,y)=n\). Let \(R^\ast (n)\) count only the pairs with \(\gcd (x,y)=1\). A nonzero vector has content \(d=\gcd (x,y)\), and \(Q(dv)=d^2Q(v)\), so \[R(n)=\sum _{d^2\mid n}R^\ast (n/d^2).\] The stabilizer in the automorph group of any primitive vector is trivial: an automorph fixing a vector has eigenvalue \(1\), hence trace \(2\) because the determinant is \(1\), hence \(t=2\) and \(u=0\). The group therefore acts freely on the proper representations of each form. It remains to show that the orbits are indexed by the residues \(b\) modulo \(2n\) with \(b^2\equiv D\pmod {4n}\).
Given a proper representation of \(n\) by a vector \(v\), complete \(v\) to a basis \((v,w)\) of determinant \(1\). In that basis the form is \(nx^2+Bxy+Cy^2\) with \(B^2-4nC=D\). Replacing \(w\) by \(w+tv\) sends \(xv+yw\) to \((x+ty)v+yw\). The term \(n(x+ty)^2\) contributes the extra middle term \(2nt\,xy\), so the middle coefficient changes by \(2nt\) and \(B\) modulo \(2n\) is invariant. An automorph changes the vector inside one orbit and does not change this residue. In the other direction, a residue \(b\) produces the positive definite form \(nx^2+bxy+cy^2\) with \(c=(b^2-D)/(4n)\). That form has discriminant \(D\), so it is equivalent to exactly one representative in \(\mathcal F\). Transporting \((1,0)\) by such an equivalence yields a proper representation with that residue. If two proper representations have the same residue \(b\), replace each second basis vector by a shear so that the middle coefficient equals \(b\). The discriminant identity then forces both coordinate forms to equal \(nx^2+bxy+cy^2\) with the same \(c=(b^2-D)/(4n)\). Those two determinant-\(1\) bases therefore belong to the same class representative. If \(M_1\) and \(M_2\) are the basis matrices, \(M_1M_2^{-1}\) carries one represented vector to the other and preserves the form, since both bases pull it back to that coordinate polynomial. The number of such residues is therefore the number of orbits, and \(R^\ast (n)=w_D\rho (n)\), where \(\rho (n)\) denotes that number of residues.
The count \(\rho \) is multiplicative on coprime arguments. If \(n_2\) is odd and coprime to \(n_1\), a residue modulo \(2n_1n_2\) is a pair of a residue modulo \(2n_1\) and a residue modulo \(n_2\). The square condition splits, and for odd \(n\) the count \(\rho (n)\) equals the number of solutions of \(v^2\equiv D\pmod n\). Indeed \(\gcd (4,n)=1\), so the condition modulo \(4n\) splits into conditions modulo \(4\) and modulo \(n\), and exactly one of the two lifts modulo \(2n\) has the parity required by \(D\) modulo \(4\). Thus \(\rho (n_1n_2)=\rho (n_1)\rho (n_2)\).
For an odd prime \(p\) the same count is the number of roots of \(v^2-D\) modulo \(p^k\). If \(p\) does not divide \(D\) and \(\chi _D(p)=1\), there are two simple roots modulo \(p\), and the derivative \(2v\) is invertible at each, so each lifts uniquely and \(\rho (p^k)=2\). If \(\chi _D(p)=-1\), there is no root and \(\rho (p^k)=0\). If \(p\) divides \(D\), then \(p\) divides \(D\) exactly once. Modulo \(p\) the only root is \(0\), so \(\rho (p)=1\). Modulo \(p^k\) with \(k\ge 2\) the valuation \(v_p(D)=1\) is odd, while a square has even valuation, so \(\rho (p^k)=0\).
At the prime \(2\), first take \(n=1\): exactly one of \(b=0,1\) satisfies \(b^2\equiv D\pmod 4\), so \(\rho (1)=1\). If \(D\) is odd and \(D\equiv 5\pmod 8\), then for \(a\ge 1\) the modulus \(2^{a+2}\) is a multiple of \(8\), and no square is congruent to \(5\) modulo \(8\), so \(\rho (2^a)=0\). If \(D\equiv 1\pmod 8\), the two odd residues modulo \(4\) satisfy the congruence modulo \(8\). A solution modulo \(2^{a+1}\) lifts to a solution modulo \(2^{a+2}\) by \(b=b_0+t2^{a+1}\). The cross term determines \(t\) uniquely because \(b_0\) is odd, and the quadratic term in \(t\) is divisible by \(2^{a+3}\). Thus \(\rho (2^a)=2\) for every \(a\ge 1\). If \(D\) is even, inspect \(b\) modulo \(4\) against the condition modulo \(8\). When \(D\equiv 4\pmod 8\) the only solution is \(b\equiv 2\pmod 4\). When \(D\equiv 0\pmod 8\) the only solution is \(b\equiv 0\pmod 4\). Thus \(\rho (2)=1\). For \(a\ge 2\) write \(D=4m\). If \(m\equiv 2\pmod 4\), then \(v_2(D)=3\). A square cannot have that valuation, and \(3\) is strictly smaller than the modulus \(2^{a+2}\), so there is no solution. If \(m\) is odd, a solution would have valuation exactly \(2\), hence the shape \(b=2c\) with \(c\) odd, and then \(c^2\equiv m\pmod 4\). An odd square is \(1\) modulo \(4\), while \(m\equiv 3\pmod 4\). There is again no solution, so \(\rho (2^a)=0\) for \(a\ge 2\).
Let \(\psi (n)=\sum _{d\mid n}\chi _D(d)\) and \(g(n)=\sum _{d^2\mid n}\rho (n/d^2)\). Both functions are multiplicative, since a square divisor of a product of coprime arguments splits, so it is enough to compare them on prime powers. If \(\chi _D(p)=1\), then \(\rho (p^j)=2\) for \(j\ge 1\). For even \(k=2m\) the sum \(g(p^k)\) is \(m\) terms equal to \(2\) and one term \(\rho (1)\), hence \(k+1\). For odd \(k=2m+1\) it is \(m+1\) terms equal to \(2\), hence again \(k+1\). The character sum is the same geometric sum. If \(\chi _D(p)=-1\), then \(\rho (p^j)=0\) for \(j\ge 1\), so \(g(p^k)\) keeps only \(\rho (1)\) when \(k\) is even and is \(0\) when \(k\) is odd. The alternating character sum has those same two values. If \(\chi _D(p)=0\), then \(\rho (p)=1\) and \(\rho (p^j)=0\) for \(j\ge 2\), so every \(g(p^k)\) equals \(1\), as does \(\psi (p^k)\). Therefore \(g=\psi \), and \[R(n)=w_D\sum _{d\mid n}\chi _D(d).\]
Absolute convergence for \(\operatorname {Re}s>1\) lets the zeta sums be rearranged. The form has no real root and \(a>0\), so its minimum \(\mu \) on the unit circle is positive and \(Q(x,y)\ge \mu (x^2+y^2)\). The comparison series converges for \(\operatorname {Re}s>1\) because, in polar coordinates, the tail is a constant multiple of \(\int _1^\infty r^{1-2s}\,dr\). Hence \[\sum _{Q\in \mathcal F}E_Q(s) =\sum _{n\ge 1}R(n)\,n^{-s}.\] The representation count and the substitution \(n=dm\) give \[w_D\sum _{d,m\ge 1}\chi _D(d)\,(dm)^{-s} =w_D\,\zeta (s)\sum _{d\ge 1}\chi _D(d)\,d^{-s}.\] Complete multiplicativity expands each Euler factor \((1-\chi _D(p)p^{-s})^{-1}\) as a geometric series. The product in the center note is therefore the Dirichlet series, which is the identity claimed above.
For the illustration \(D=-4\), repeat the shear \(\begin {pmatrix}1&k\\0&1\end {pmatrix}\), which replaces \(b\) by \(b+2ak\) and does not change \(a\), until \(|b|\le a\). Whenever \(a>c\), apply \(\begin {pmatrix}0&-1\\1&0\end {pmatrix}\). That matrix exchanges the outer coefficients and changes the sign of the middle coefficient, so it replaces \(a\) by the smaller positive integer \(c\). Each such swap decreases \(a\), and the process stops at a representative with \(|b|\le a\le c\). Then \(b\) is even, \(ac=(b/2)^2+1\), and \(a^2\le ac\le a^2/4+1\), so \(a=1\), \(b=0\), and \(c=1\). The only class is \(x^2+y^2\), and \(w_{-4}=4\).
The identity concerns binary forms. The four-cycle precision has rank \(4\). Schiemann's papers of 1990 and 1997, which have not been read here, are not a step in the argument: this section does not claim that one theta series separates a quaternary form from the other forms in its genus.
The Weil index remains speculative. No product of local indices is proved here, and Weil's paper of 1964 has not been read for this note. The class sum does not identify an Epstein zeta with the real normalizer.
Continuum approximation [fdip-004F]AGENTDRAFTED
- November 1, 2026
Continuum approximation [fdip-004F]AGENTDRAFTED
- November 1, 2026
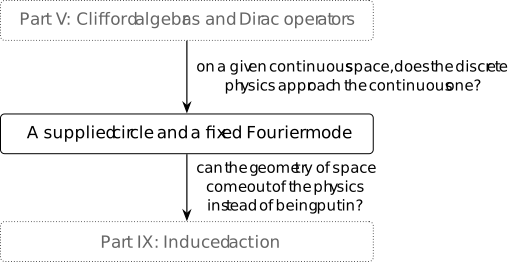
On a given continuous space, does the discrete physics approach the continuous one? The spatial Dirac calculation used lattice spacing one. Now supply a circle and place the graph on it. There are finitely many sites; the field values may still be real. For a field that changes over many vertices, the spacing is small relative to the scale of that change. Dividing an edge difference by the spacing then suggests a derivative. Continuous values concern the allowed field values, here real numbers; differentiability concerns the variation of a field on the supplied space and limits of difference quotients. Smoothness asks for derivatives of every order.
The circle calculation makes a limited comparison precise: each fixed Fourier mode of the discrete operator approaches its counterpart on the supplied circle. Approximation needs comparison maps and a limit; the chapter states these together with its pairings, positive precision and Gaussian moments. The circle is an input, so this result does not construct continuous space from the graph. The finite Dirac kernel in Proposition [fdip-000T] depends on the parity of the periods; that separate calculation cautions against inferring a general continuum theory from one fixed-mode limit. Whether continuous-space physics can be recovered at large scales without supplying the space remains open here.
A supplied circle and a fixed Fourier mode [fdip-004G]AGENTDRAFTED
- October 31, 2026
A supplied circle and a fixed Fourier mode [fdip-004G]AGENTDRAFTED
- October 31, 2026
How does a finite operator approximate a differential operator when the circle and its length are already given? A periodic mesh, a normalized pairing and a positive mass give an explicit answer for each fixed Fourier mode. The same calculation controls one Gaussian second moment, using normalization and inverse-precision covariance. The spatial Dirac comparison provides related finite symbols; the scalar argument below does not require its Clifford module.
Definition. A circle mesh with normalized pairing [fdip-004H]AGENTDRAFTED
- October 31, 2026
Definition. A circle mesh with normalized pairing [fdip-004H]AGENTDRAFTED
- October 31, 2026
Supply the unit circle \(\mathbb R/\mathbb Z\), its coordinate \(x\) modulo one and length measure \(dx\). For an integer \(n\geq 3\), the circle mesh consists of the points \(j/n\), with \(j\in \mathbb Z/n\mathbb Z\), and spacing \(h_n=1/n\). Its real field space and reference pairing are \[E_n=\mathbb R^{\mathbb Z/n\mathbb Z},\qquad g_{0,n}(f,g)=\frac 1n\sum _{j=0}^{n-1}f_jg_j.\] On the complexification use \(\langle f,g\rangle _n=n^{-1}\sum _j\overline {f_j}g_j\); its restriction to real fields is \(g_{0,n}\).
Fix a mass squared \(\mu >0\), independent of \(n\). Define the cyclic shift, scaled nearest-neighbor Laplacian and precision by \[\begin {aligned} (T_nf)_j&=f_{j+1},\\ L_n&=n^2(2I-T_n-T_n^{-1}),\\ Q_n&=\mu I+L_n,\qquad q_n(f)=g_{0,n}(f,Q_nf). \end {aligned}\] Indices are taken modulo \(n\). These specialize the cyclic shift and difference energy, with the supplied scale \(n^2\). The scalar \(L_n\) is the nearest-neighbor operator compared with, and generally different from, the centered Dirac square in Proposition [fdip-000T].
Periodic reindexing gives \(T_n^*=T_n^{-1}\) in the normalized pairing. Consequently \[\langle f,L_nf\rangle _n =n\sum _{j=0}^{n-1}|f_{j+1}-f_j|^2\geq 0.\] Thus \(Q_n\geq \mu I\) and \(Q_n\) is invertible, including on constant fields. This is the positive precision convention with the declared \(g_{0,n}\), rather than a change of the action form.
The step-function interpolation \(I_n\) assigns to \(f\) the function with value \(f_j\) whenever \(j/n\leq x<(j+1)/n\), using the representative \(0\leq x<1\). It maps real or complex fields into \(L^2(\mathbb R/\mathbb Z,dx)\), the square-integrable functions modulo almost-everywhere equality. Each interval has length \(1/n\), so \[\|I_nf\|_{L^2}^2=\frac 1n\sum _j|f_j|^2=\|f\|_n^2.\] Thus the comparison preserves the specified norm.
Example. Fourier modes and their Gaussian moments on a circle mesh [fdip-004I]AGENTDRAFTED
- October 31, 2026
Example. Fourier modes and their Gaussian moments on a circle mesh [fdip-004I]AGENTDRAFTED
- October 31, 2026
For the circle mesh, let \(k\in \mathbb Z\) and set \[e_k(x)=e^{2\pi ikx},\qquad e_{n,k}(j)=e^{2\pi ikj/n}.\] Every entry has modulus one, hence \(\|e_{n,k}\|_n=1\). Applying the shift and its inverse directly gives \[\begin {aligned} T_ne_{n,k}&=e^{2\pi ik/n}e_{n,k},\\ L_ne_{n,k}&=\lambda _{n,k}e_{n,k},\\ \lambda _{n,k} &=n^2(2-e^{2\pi ik/n}-e^{-2\pi ik/n})\\ &=4n^2\sin ^2(\pi k/n). \end {aligned}\] This derives the scaled version of the nearest-neighbor symbol. Frequencies differing by \(n\) give the same samples. For fixed \(k\ne 0\), the condition \(n>2|k|\) separates \(k\) from \(-k\) modulo \(n\).
For \(k=0\), \(e_{n,0}=\mathbf 1\) and \(\lambda _{n,0}=0\). For \(k=1\), a four-point mesh has \(\lambda _{4,1}=32\); an eight-point mesh has \(\lambda _{8,1}=64(2-\sqrt 2)\). The picture shows the supplied unit circle sampled at 4 equally spaced points. Its arrows indicate increasing \(j\); they do not specify a dynamics.
Now use real fields and the Gaussian law \[d\nu _n(f)=Z_n^{-1}e^{-q_n(f)/2}\,d\operatorname {vol}_{g_{0,n}}(f).\] In raw coordinates the volume and normalization are \[\begin {aligned} d\operatorname {vol}_{g_{0,n}}&=n^{-n/2}\,df_0\cdots df_{n-1},\\ Z_n&=(2\pi )^{n/2}(\det Q_n)^{-1/2}. \end {aligned}\] The volume factor follows because \(f\mapsto f/\sqrt n\) is an orthonormal chart; the partition function is Theorem [fdip-002T]. The covariance operator relative to \(g_{0,n}\) is \(Q_n^{-1}\) by Theorem [fdip-000B]. Since the exponent is \(f^TQ_nf/(2n)\), the raw coordinate covariance matrix is \(nQ_n^{-1}\).
Define the complex Fourier observable \(a_{n,k}=n^{-1}\sum _j e^{-2\pi ikj/n}f_j\). It has zero mean. Writing \(v=e_{n,k}\) and \(v^*\) for its conjugate transpose, the coordinate covariance gives \[\begin {aligned} \mathbb E_{\nu _n}|a_{n,k}|^2 &=n^{-2}v^*(nQ_n^{-1})v\\ &=\frac 1{\mu +\lambda _{n,k}}, \end {aligned}\] because \(v^*v=n\). All real and imaginary parts and their products are integrable polynomials by Proposition [fdip-002W]. In particular the real mean \(a_{n,0}\) has variance \(1/\mu \). At \(k=1\), the four-point and eight-point second moments are respectively \((\mu +32)^{-1}\) and \((\mu +64(2-\sqrt 2))^{-1}\).
For \(k\ne 0\) and \(n>2|k|\), put \[\begin {aligned} c_{n,k}&=\operatorname {Re}a_{n,k} =\frac 1n\sum _j\cos (2\pi kj/n)f_j,\\ s_{n,k}&=-\operatorname {Im}a_{n,k} =\frac 1n\sum _j\sin (2\pi kj/n)f_j. \end {aligned}\] The geometric sum \(\sum _j e^{4\pi ikj/n}=0\): its ratio is not one, its \(n\)-th power is one, and multiplying the sum by one minus the ratio gives zero. Taking real and imaginary parts, and using the double-angle identities, gives normalized squared norms \(1/2\) for both the cosine and sine vectors and their orthogonality. Both vectors have precision eigenvalue \(\mu +\lambda _{n,k}\), so Theorem [fdip-000B] yields \[\operatorname {Var}(c_{n,k})=\operatorname {Var}(s_{n,k}) =\frac 1{2(\mu +\lambda _{n,k})}.\] The coefficients of the orthogonal projection \(A\cos (2\pi kj/n)+B\sin (2\pi kj/n)\) are \(A=2c_{n,k}\), \(B=2s_{n,k}\). Their variances are 4 times the displayed projection variances.
The character calculation and normalization above are direct
deductions from the cited finite operators and Gaussian results.
Mathlib's ZMod.dft uses the counting-measure forward sum;
\(a_{n,k}\) has the additional factor \(1/n\). This formal Fourier
transform is a supporting construction, not a formalization of the
mesh limit.
Proposition. A fixed Fourier mode and its massive inverse converge [fdip-004J]AGENTDRAFTED
- October 31, 2026
Proposition. A fixed Fourier mode and its massive inverse converge [fdip-004J]AGENTDRAFTED
- October 31, 2026
Use the circle meshes with fixed \(\mu >0\), and fix \(k\in \mathbb Z\) before letting \(n\to \infty \). For the Fourier modes and eigenvalues, \[\begin {aligned} \lambda _{n,k}&\longrightarrow 4\pi ^2k^2,\\ (\mu +\lambda _{n,k})^{-1} &\longrightarrow (\mu +4\pi ^2k^2)^{-1}. \end {aligned}\] Moreover, in \(L^2(\mathbb R/\mathbb Z,dx)\), \[I_nQ_n^{-1}e_{n,k} \longrightarrow (\mu +4\pi ^2k^2)^{-1}e_k.\] The vector on the right solves \(Au=e_k\) for \(A=-d^2/dx^2+\mu \) on smooth periodic functions. The selected Gaussian moment \(\mathbb E_{\nu _n}|a_{n,k}|^2\) converges to the same inverse eigenvalue.
Proof.
- October 31, 2026
Proof.
- October 31, 2026
For \(k=0\), the eigenvalue is identically zero and the sampled constant interpolates exactly to \(e_0=1\); all three assertions follow. For \(k\ne 0\), \[\lambda _{n,k} =4\pi ^2k^2\left (\frac {\sin (\pi k/n)}{\pi k/n}\right )^2.\] The sine quotient tends to one. Since \(\mu >0\), all denominators are at least \(\mu \), so continuity of inversion proves the scalar inverse limit.
For \(j/n\leq x<(j+1)/n\), the elementary inequality \(|e^{it}-e^{is}|\leq |t-s|\) gives \[|I_ne_{n,k}(x)-e_k(x)|\leq \frac {2\pi |k|}{n}.\] The inequality follows by integrating \(ie^{iu}\) between \(s\) and \(t\). The circle has measure one, hence the same bound holds for the \(L^2\) norm. Put \(b_n=(\mu +\lambda _{n,k})^{-1}\) and \(b=(\mu +4\pi ^2k^2)^{-1}\). Because \(|b_n|\leq 1/\mu \) and \(\|e_k\|_{L^2}=1\), \[\begin {aligned} \|b_nI_ne_{n,k}-be_k\|_{L^2} &\leq |b_n|\|I_ne_{n,k}-e_k\|_{L^2}+|b_n-b|\\ &\leq \frac {2\pi |k|}{\mu n}+|b_n-b|\longrightarrow 0. \end {aligned}\] The eigenvector equation identifies the left vector with \(I_nQ_n^{-1}e_{n,k}\). Differentiation gives \(Ae_k=(\mu +4\pi ^2k^2)e_k\). Finally the Gaussian second-moment formula in Example [fdip-004I] is exactly \(b_n\).
This is an elementary limit deduction from the preceding finite
symbol, with an explicit interpolation map. Mathlib's
Real.tendsto_sin_div_nhdsNE_zero supplies the nonzero
sine-quotient limit used in the proof; the zero mode was handled
separately. The declaration does not supply the interpolation or
Gaussian comparison.
Remark. What the supplied-circle limit establishes [fdip-004K]AGENTDRAFTED
- October 31, 2026
Remark. What the supplied-circle limit establishes [fdip-004K]AGENTDRAFTED
- October 31, 2026
The fixed-mode limit compares finite operators and one Gaussian moment with a declared circle. Its length, measure, mesh spacing, factor \(n^2\) and positive mass are supplied. Without \(n^2\), each fixed-mode Laplacian eigenvalue tends to zero. This explains why a finite positive operator alone does not determine a continuum scale or geometry.
The quantifier on the frequency matters. For even \(n\) and \(k=n/2\), the discrete eigenvalue is \(4n^2\), whereas the continuum frequency has eigenvalue \(4\pi ^2k^2=\pi ^2n^2\). Their ratio stays \(4/\pi ^2\); the fixed-mode proof is therefore not a relative uniform estimate over all modes. It proves neither operator-norm resolvent convergence nor convergence of determinants or Gaussian measures. Removing the positive mass or adding interactions requires additional arguments.
For comparison, Weisz distinguishes the critical-point and phase-diagram control needed for low-energy lattice-QCD continuum limits from the renormalization questions for composite observables and high-energy scales [weisz2010renormalization, Section 1.1, printed p. 2]. The circle calculation is a much smaller prescribed approximation: it contains no interacting critical-point analysis. It establishes no emergent geometry, reflection positivity, Lorentzian reconstruction, Standard Model dynamics or gravitational dynamics. Those identifications remain among the open physical interfaces.
Realization and the information retained by observables [fdip-004L]AGENTDRAFTED
- November 1, 2026
Realization and the information retained by observables [fdip-004L]AGENTDRAFTED
- November 1, 2026
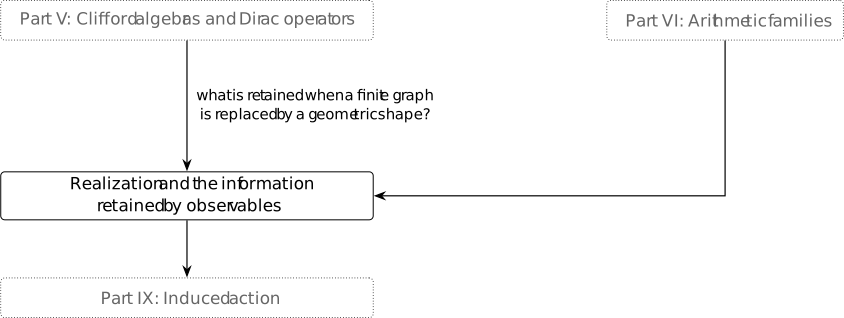
What is retained when a finite graph is replaced by a geometric shape? A graph records points and the links between them. One way to give it a shape is to assign an interval to each edge of its incidence presentation and join the intervals at their endpoints. Three edges in a cycle give a triangle's boundary; the graph alone does not choose its filling.
The retained Gaussian law gives a sharper test of the information preserved. Forget an edge weight while keeping its endpoint: two weights can then give the same interval but different variances at that endpoint. This is a small teaching variant of the weighted-cycle comparison, governed by the existing fiber-constancy criterion. An observable descends through the replacement exactly when it is constant on the data that the replacement identifies. Forgetting a weight can erase a retained observable even when the geometric construction is well-defined.
The enriched background comparison preserves observables only when the required data and the observables are transported together. The examples below identify what is forgotten and keep scalar factorization separate from categorical localization and gluing over covers. The shape is built by hand, just as the preceding approximation supplied its circle. Neither comparison supplies an emergent geometry or gluing theorem.
Definition. One-dimensional realization of finite incidence [fdip-004M]AGENTDRAFTED
- October 31, 2026
Definition. One-dimensional realization of finite incidence [fdip-004M]AGENTDRAFTED
- October 31, 2026
Let \(G=(V,E,s,h)\) be a finite incidence presentation. Its one-dimensional realization is the quotient space \[|G|=\bigl (V\sqcup (E\times [0,1])\bigr )/{\sim },\] where \(V,E\) are discrete, the intervals have their usual topology, and the equivalence relation is generated by \[(e,0)\sim s(e),\qquad (e,1)\sim h(e).\] Use the quotient topology. Thus each vertex is a point and each edge supplies an open interval attached at its endpoints, the standard one-dimensional CW construction of [hatcher2002algebraic, Section 1.A, p. 83]. Loops have both endpoints attached at one vertex; parallel edges remain separate intervals. Direction chooses the parametrization from \(0\) to \(1\), not a causal ordering.
Declare a morphism \(f:G\to G'\) to be a pair of maps \(f_V:V\to V'\) and \(f_E:E\to E'\) with \[f_Vs=s'f_E,\qquad f_Vh=h'f_E.\] It induces \[\begin {aligned} |f|:|G|&\longrightarrow |G'|,\\ [v]&\longmapsto [f_V(v)],\\ [e,t]&\longmapsto [f_E(e),t]. \end {aligned}\] These formulas respect the endpoint identifications. They are continuous before quotienting, so the quotient topology makes \(|f|\) continuous. Identity and composition follow from the formulas. This proves functoriality for these declared incidence maps; arbitrary edge contractions have not been included among them. The map construction is a direct deduction from the quoted quotient model.
Example. A triangle boundary and a filled triangle [fdip-004N]AGENTDRAFTED
- October 31, 2026
Example. A triangle boundary and a filled triangle [fdip-004N]AGENTDRAFTED
- October 31, 2026
Take the simple undirected triangle on vertices \(\{0,1,2\}\). Give its three edges any orientations, then forget them here; any parallel copies would also have to be merged before this simple undirected comparison. The one-dimensional realization retains the three edges without a face. In the nonempty-face convention of [maypishevar2025finitespaces, Definition 6.1.1, p. 61], its boundary complex and the filled complex have faces \[\begin {aligned} K_{\partial } &=\{\{0\},\{1\},\{2\},\{0,1\},\{1,2\},\{0,2\}\},\\ K_{\Delta }&=K_{\partial }\cup \{\{0,1,2\}\}. \end {aligned}\] The added face consists of three pairwise adjacent vertices: it is the filled clique triangle. This specifies these two complexes, without declaring a general clique-construction functor.
Choose three noncollinear points \(v_0,v_1,v_2\) in the plane. Realize each listed face by the convex hull of its vertices, as in [maypishevar2025finitespaces, Definitions 6.2.1 and 6.2.6, pp. 62-63]. Then \(|K_{\partial }|\) is the perimeter and \(|K_{\Delta }|\) is the closed triangular region. Traversing the three line segments identifies the perimeter with \([0,3]/(0\sim 3)\): the induced map is a continuous bijection from a compact space to a Hausdorff space, hence a homeomorphism. The map \(t\mapsto \exp (2\pi i t/3)\) gives the same identification with \(S^1\).
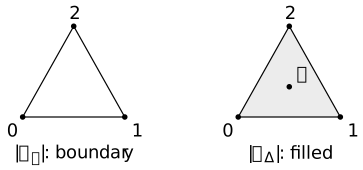
The filled triangle contracts to its barycenter \(b=(v_0+v_1+v_2)/3\) by \[H(x,t)=(1-t)x+tb,\qquad 0\leq t\leq 1.\] Convexity keeps \(H(x,t)\) in the triangle, and the formula is continuous, with \(H(x,0)=x\) and \(H(x,1)=b\). The two constructions have the same vertices and edges, but only the second supplies a two-dimensional face. Incidence alone therefore does not choose between keeping the perimeter and filling it. Each specified realization is nevertheless a well-defined construction.
These comparisons are elementary deductions from the cited
realization definitions. Mathlib's AbstractSimplicialComplex
uses nonempty faces and includes each vertex; its
Convex.contractibleSpace supplies contractibility of a
nonempty convex subset of a real topological vector space. These
support the conventions and the contraction step, not the complete
incidence-to-triangle comparison.
Definition. Forgetting a weight while retaining its endpoint [fdip-004O]AGENTDRAFTED
- October 31, 2026
Definition. Forgetting a weight while retaining its endpoint [fdip-004O]AGENTDRAFTED
- October 31, 2026
For each \(w>0\), let \(\mathcal B_w\) be the finite Gaussian background with vertices \(V=\{0,1\}\), one edge \(0\to 1\) of weight \(w\), counting pairing, mass \(m=1\), retained set \(R=\{0\}\) and eliminated set \(V\setminus R=\{1\}\). The field coordinates remain labelled. The weighted Laplacian and massive precision are \[\begin {aligned} L_w&=w\begin {pmatrix}1&-1\\-1&1\end {pmatrix},\\ Q_w&=I+L_w=\begin {pmatrix}1+w&-w\\-w&1+w\end {pmatrix}. \end {aligned}\] Indeed the incidence row is \((-1,1)\). The vectors \((1,1)\) and \((1,-1)\) have precision eigenvalues \(1\) and \(1+2w\), so \(Q_w>0\). The normalized Gaussian law is therefore well-defined on counting-coordinate volume \(df_0\,df_1\), with \[\begin {aligned} d\mu _w(f)&=Z_w^{-1}\exp (-f^TQ_wf/2)\,df_0\,df_1,\\ Z_w&=\frac {2\pi }{\sqrt {1+2w}}. \end {aligned}\] The normalizer is the two-dimensional specialization of positive Gaussian normalization.
Let \(X=\{\mathcal B_w:w>0\}\) and let \(Y=\{U\}\) be the singleton whose element is the unweighted labelled directed edge \(0\to 1\) with distinguished endpoint \(0\). Define \[\begin {aligned} c:X&\longrightarrow Y,&c(\mathcal B_w)&=U,\\ r:X&\longrightarrow \mathbb R,&r(\mathcal B_w)&=\int f_0^2\,d\mu _w(f). \end {aligned}\] Thus \(c\) forgets the varying weight while retaining the labels, orientation and selected endpoint; the mass and reference pairing are fixed throughout the family. The observable is integrable by Gaussian polynomial integrability. The coordinate has zero mean, so \(r\) is the variance at the retained endpoint. Composing \(c\) with the interval realization gives the same labelled interval with that endpoint for every \(w\).
Example. The retained variance detects the forgotten weight [fdip-004P]AGENTDRAFTED
- October 31, 2026
Example. The retained variance detects the forgotten weight [fdip-004P]AGENTDRAFTED
- October 31, 2026
For the two-vertex family, eliminate the coordinate at vertex \(1\). The positive Schur formula and retained covariance give \[\begin {aligned} S_w&=(1+w)-\frac {w^2}{1+w} =\frac {1+2w}{1+w}>0,\\ r(\mathcal B_w)&=S_w^{-1}=\frac {1+w}{1+2w}. \end {aligned}\] In particular, \[r(\mathcal B_1)=\frac 23\ne \frac 35=r(\mathcal B_2), \qquad c(\mathcal B_1)=c(\mathcal B_2)=U.\] The fiber-constancy criterion excludes a function \(F:c(X)\to \mathbb R\) satisfying \(r=F\circ c\), even on a restricted family containing these two backgrounds. Consequently the unweighted interval with its retained endpoint also cannot recover this variance on that family. This is an obstruction for the specified forgetting and observable, not for every geometric realization.
This two-coordinate calculation is a teaching variant of the weighted-cycle comparison, which already gives unequal retained correlations \(2/15\) and \(16/105\) at fixed mass and fixed retained pair. The same principle is visible with one retained coordinate: incidence and the selected endpoint do not retain the weighted precision. By contrast, weight-preserving relabelings, with the retained projection and observable transported together, preserve expectations by Gaussian transport. Enlarging their comparison to forget weights need not preserve them.
Remark. Scalar factorization, localization and gluing [fdip-004Q]AGENTDRAFTED
- October 31, 2026
Remark. Scalar factorization, localization and gluing [fdip-004Q]AGENTDRAFTED
- October 31, 2026
The retained-variance example tests scalar factorization: for specified functions \(c:X\to Y\) and \(r:X\to \mathbb R\), it asks whether \(r=F\circ c\) for a function on \(c(X)\). The fiber criterion answers exactly this question, without supplying continuity or any categorical structure.
Functorial factorization instead starts with categories and
functors \(U:\mathcal B\to \mathcal D\) and
\(O:\mathcal B\to \mathcal A\), and asks for
\(\overline O:\mathcal D\to \mathcal A\) and a
natural isomorphism
\(O\cong \overline O\circ U\). A localization at a declared
class \(W\) of arrows has an additional universal property: it
inverts those arrows and is universal among functors that do so
[stacks2017stacks, Section 4.27], Tag 04VB.
A generic forgetful functor is not thereby a localization.
Mathlib's CategoryTheory.Localization.lift requires
both a localization functor and a functor that inverts \(W\);
these hypotheses are absent from the scalar example.
Local-to-global descent requires a site with covers, restriction maps and compatible data on overlaps, together with an effective gluing statement. For category-valued data, a stack also requires a fibred category and sheaves of morphisms [stacks2017stacks, Definition 8.4.1], Tag 0268. The enriched background groupoid and the scalar variance calculation supply none of this cover-and-gluing structure. The groupoid is a category of finite backgrounds, not necessarily a finite category. No local-to-global descent theorem follows.
Selected backgrounds and invariants [fdip-0059]AGENTDRAFTED
- November 1, 2026
Selected backgrounds and invariants [fdip-0059]AGENTDRAFTED
- November 1, 2026
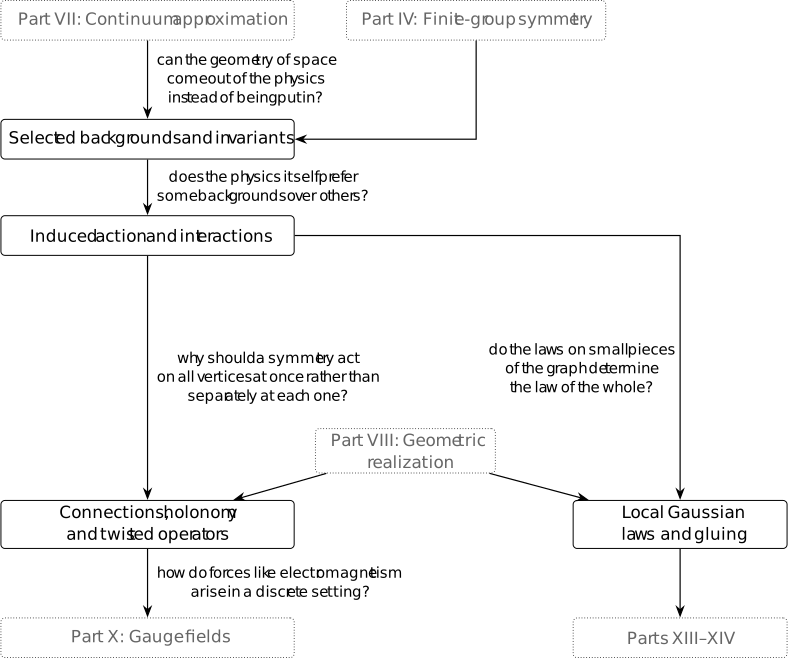
Can geometry be induced instead of supplied? Edge weights set the stiffness of field differences and may encode geometric information; they are not universally distances. Comparing choices through an induced action first requires keeping the graph data distinct from the choice of which field to retain. A retained field need not consist of named vertex coordinates. It may be a symmetry sector, or another specified subspace of the vertex fields. An orthogonal projector records this choice relative to the counting metric. Integrating out its orthogonal complement produces a Gaussian law on the chosen subspace.
The graph and its selector remain separate data. A graph relabeling must transport both, while an arbitrary orthogonal comparison of precisions can forget incidence. The examples below compare three selectors on one four-cycle and two rank-4 selectors on a quaternion Cayley graph. Their retained spectra separate choices that the unselected graph cannot distinguish. The restriction criterion then identifies exactly when eliminating the complement changes the compressed precision; a stable prism line shows why group symmetry alone is insufficient. In this chapter \(\Gamma \) denotes a symmetry group and \(G=Q^{-1}\) denotes the Green operator.
Definition. A selected Gaussian background [fdip-005A]AGENTDRAFTED
- November 1, 2026
Definition. A selected Gaussian background [fdip-005A]AGENTDRAFTED
- November 1, 2026
A selected Gaussian background is a tuple \[b=(\Pi ,w,m,P),\qquad \Pi =(V,E,s,h),\] where \(\Pi \) is a finite incidence presentation, \(w:E\to \mathbb R_{>0}\), \(m>0\), and \(P\) is an orthogonal projector on the counting inner-product space \(H=\mathbb R^V\), with \[P^2=P=P^*,\qquad 0<\operatorname {rank}P<|V|.\] The selected space is \(X=\operatorname {im}P\), its orthogonal complement is \(Y=\ker P\), and the observed random vector is \(P\phi \in X\). Incidence, the Green operator and the full law are \[\begin {aligned} (d\phi )(e)&=\phi (h(e))-\phi (s(e)),\\ Q&=d^*Wd+m^2I>0,\qquad G=Q^{-1},\\ \phi &\sim \mu _Q. \end {aligned}\] Here \(W=\operatorname {diag}(w)\) and \(\mu _Q\) uses the induced Euclidean volume. These are derived from the tuple, not additional choices.
Three constructions supply such projectors, provided their ranks are nonzero and proper.
- A retained subset \(R\subsetneq V\) gives \(P_R\phi =\sum _{v\in R}\phi (v)\delta _v\). Identifying \(\operatorname {im}P_R\) with \(\mathbb R^R\) recovers the coordinate background.
- A finite signed graph symmetry \(\rho :\Gamma \to O(H)\) extends to \(\mathbb R[\Gamma ]\). For \(e^2=e=e^*\), where \([g]^*=[g^{-1}]\), \(P=\rho (e)\) is orthogonal because \(\rho (e)^*=\rho (e^*)\). The precision commutes with every \(\rho (g)\), hence with this \(P\).
- For a \(\Gamma \)-stable subspace \(X\subset H\), its orthogonal projector commutes with \(\rho (\Gamma )\): orthogonality makes \(X^\perp \) stable too. It need not commute with \(Q\). Within a repeated real isotypic block, the chosen multiplicity subspace may fail to be invariant under the positive multiplicity matrix. These are different constructions: a subrepresentation projector commutes with \(\rho (\Gamma )\) but need not commute with \(Q\); a group-algebra projector commutes with \(Q\) but need not commute with \(\rho (\Gamma )\). Centrality of \(e\) is sufficient for the latter commutation, and hence for a stable image.
Every subspace has a unique orthogonal projector for the specified metric. This makes the selector equivalent to choosing \(X\), without choosing an additional complementary subspace. An oblique idempotent \(T^2=T\) also gives a Gaussian observation \(T\phi \), and orthogonal conjugation does transport it naturally: \(T\mapsto OTO^{-1}\). But it also records a possibly nonorthogonal kernel, so the image alone no longer determines the observation or its covariance \(TGT^*\). General linear observations are outside this definition. No physical rule selecting \(P\) from an environment is assumed.
Theorem. The law on a selected subspace [fdip-005B]AGENTDRAFTED
- November 1, 2026
Theorem. The law on a selected subspace [fdip-005B]AGENTDRAFTED
- November 1, 2026
For a selected background, view \(P\) as a map \(H\to X=\operatorname {im}P\) and let \(r=\dim X\). The law \(\nu _b=P_*\mu _Q\) is the centered Gaussian on \(X\) with intrinsic covariance and precision \[C_P=(PGP)|_X>0,\qquad S_P=C_P^{-1}:X\to X.\] Relative to the induced Euclidean volume \(\lambda _X\), its density is \[\frac {d\nu _b}{d\lambda _X}(x) =\frac {\sqrt {\det _X S_P}}{(2\pi )^{r/2}} e^{-\langle x,S_Px\rangle /2}.\] If \(B:\mathbb R^r\to H\) is an isometric inclusion with image \(X\), then \(BB^*=P\); its chosen coordinate matrices are \[B^*C_PB=B^*GB,\qquad [S_P]_B=(B^*GB)^{-1}.\] For another such basis \(B'=BU\), \(U\in O(r)\), the latter changes to \(U^*[S_P]_BU\). The intrinsic operator \(S_P\) is independent of this choice.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For nonzero \(x\in X\), \(\langle x,C_Px\rangle =\langle x,Gx\rangle >0\). Set \(C=B^*GB\), so \(C>0\). The positive square roots of \(Q\) and \(C\) exist by the real spectral theorem. The density change of variables \(z=Q^{1/2}\phi \) gives the standard Gaussian density \((2\pi )^{-|V|/2}e^{-|z|^2/2}\): its Jacobian and the normalizer cancel. Put \[T=C^{-1/2}B^*Q^{-1/2}.\] Then \(TT^*=C^{-1/2}(B^*GB)C^{-1/2}=I_r\), so its rows extend to an orthonormal basis of \(H\). The resulting square orthogonal matrix carries \(z\) to a standard Gaussian, since its Jacobian has absolute value one and it preserves the squared norm. Its first \(r\) coordinates are \(Tz\); integration over the other coordinates gives the standard \(r\)-dimensional density. Hence \[B^*\phi =C^{1/2}Tz\] has density \((2\pi )^{-r/2}(\det C)^{-1/2} e^{-y^TC^{-1}y/2}\) by an invertible change of variables. The isometry \(B\) carries Euclidean volume to \(\lambda _X\) and \(B(B^*\phi )=P\phi \). This proves the law and its density, rather than inferring a law from its covariance alone.
For \(x,x'\in X\), the covariance of the corresponding linear observations is \(\langle x,Gx'\rangle =\langle x,C_Px'\rangle \) by the inverse-precision formula. The inverse identity and \(B'=BU\) give the coordinate statements.
In the orthogonal split \(H=X\oplus Y\), write \[Q=\begin {pmatrix}A&K\\K^*&D\end {pmatrix},\qquad D>0.\] Then \[S_P=A-KD^{-1}K^*.\] Indeed, solving \(Q(x,y)=(u,0)\) gives \(y=-D^{-1}K^*x\) and \((A-KD^{-1}K^*)x=u\). Positivity follows by evaluating the quadratic form on \((x,-D^{-1}K^*x)\). Thus the \(X,X\) block of \(Q^{-1}\) is the inverse of this Schur complement, and it is exactly \(C_P\). For \(P=P_R\), this recovers the coordinate marginal. If \(PQ=QP\), then \(K=0\) and \(S_P=Q|_X\); symmetry of a subspace alone does not justify that equality.
[rasmussen2006gaussian, Appendix A.2, p. 200] gives formulas (A.4)-(A.6) for Gaussian densities and marginals.
[friedli2017statistical, Definition 8.3, p. 384] characterizes Gaussian vectors by linear observations.
[friedli2017statistical, Theorem 8.4, p. 385] gives their nonsingular density. The row-isometry argument above supplies the linear-image step, including its Euclidean-volume identification.
A partial formal correspondence is supplied by TauCeti's
TauCeti.Probability.map_affine_multivariateGaussian.
It allows finite real coordinate spaces, a positive semidefinite
covariance and an arbitrary rectangular linear map. Set its mean
and shift to zero, its covariance to \(G=Q^{-1}>0\), and its matrix
to \(B^*\). After the precision-density identification,
the result gives the coordinate image law with covariance \(B^*GB\).
It does not require full row rank. Positivity of this compressed
covariance, its inverse precision, the isometric identification
with \(X\), and the graph data are the additional arguments above.
Definition. Arrows of selected backgrounds [fdip-005C]AGENTDRAFTED
- November 1, 2026
Definition. Arrows of selected backgrounds [fdip-005C]AGENTDRAFTED
- November 1, 2026
The groupoid \(\mathsf {Bg}\) has selected backgrounds as objects. An arrow \(b\to b'\) is a pair of bijections \(p:V\to V'\), \(q:E\to E'\) satisfying \[\begin {aligned} s'q&=ps,&h'q&=ph,\\ w'q&=w,&m'&=m,\\ P'&=UPU^{-1},&&(U\phi )(p(v))=\phi (v). \end {aligned}\] Here \(U:H\to H'\) is the vertex counting isometry, distinct from the selector \(P\). For coordinate selectors the last equation is equivalent to \(pR=R'\), so these are precisely the exact relabelings.
The larger groupoid \(\mathsf {Bg}^{\pm }\) allows signed endpoint arrows: an additional sign \(\varepsilon (e)\in \{+,-\}\) specifies whether \(q(e)\) has endpoints \((ps(e),ph(e))\) or \((ph(e),ps(e))\). Weights, mass and the selector obey the same equations. The signed edge map is \((Ja)(q(e))=\varepsilon (e)a(e)\), where the sign acts as \(\pm 1\). Then \(d'U=Jd\) and \(W'J=JW\). Consequently \[Q'=UQU^{-1},\qquad G'=UGU^{-1}.\] The endpoint condition is retained even for loops of zero incidence. Signs are part of an arrow, not merely an equation between Laplacians.
Compose vertex and edge bijections, and for signed arrows use \[\varepsilon _{21}(e)=\varepsilon _2(q_1(e))\varepsilon _1(e).\] The identity has identity bijections and positive signs; the inverse has inverse bijections and sign \(\varepsilon (e)\) at \(q(e)\). The endpoint-arrow proof checks all graph equations. Selector transport also composes because \(P''=U_2U_1P(U_2U_1)^{-1}\). It inverts by conjugating back. These operations therefore give groupoids on the stated tuples.
Restrict \(U\) to the isometry \(U_X:X\to X'\) of selected spaces. Then the selected laws satisfy \[\begin {aligned} C_{P'}&=U_XC_PU_X^{-1},\\ S_{P'}&=U_XS_PU_X^{-1},\\ (U_X)_*\nu _b&=\nu _{b'}. \end {aligned}\] For the first identity insert \(P'=UPU^{-1}\) and \(G'=UGU^{-1}\); inversion gives the second. The full-law transport gives \(U_*\mu _Q=\mu _{Q'}\), while \(P'U=U_XP\). Composition of Borel pushforwards proves the third. In particular, for an integrable retained observable \(F'\) on \(X'\), \[\int _{X'}F'\,d\nu _{b'}=\int _X F'\circ U_X\,d\nu _b.\] The equality for \(|F'|\), allowing infinity, first establishes the matching integrability condition.
These arrows carry incidence, not only the precision and projector. Replacing one edge of weight \(w\) by two parallel edges with the same endpoints and positive weights summing to \(w\) leaves \(Q\) unchanged, but changes \(|E|\); it admits no arrow in either groupoid. Reversing the orientation of a specified edge gives an identity-on-vertices signed arrow with negative sign on that edge. That particular correspondence is not directed. Another directed isomorphism may exist if the graph has additional symmetries.
Definition. The orthogonal comparison of selected precisions [fdip-005D]AGENTDRAFTED
- November 1, 2026
Definition. The orthogonal comparison of selected precisions [fdip-005D]AGENTDRAFTED
- November 1, 2026
The orthogonal comparison of selected precisions is \[(Q,P)\sim _O(Q',P')\] when there is an orthogonal isomorphism \(O:H\to H'\) with \(Q'=OQO^{-1}\) and \(P'=OPO^{-1}\). It is an equivalence relation by identity, inverse and composition. Every background arrow supplies such a comparison. The same proof transports the selected law by \(O|_X\), but an arbitrary \(O\) need not transport vertex or edge labels. This relation differs both from the scaled Laplacian relation, which forgets mass and selector, and from general linear transport, which may change the specified metric.
The cospectral graph example proves that this comparison can identify selected backgrounds with nonisomorphic graphs. Their graph and orthogonal stabilizers also carry different information.
Example. Cospectral graphs with the same selector [fdip-005H]AGENTDRAFTED
- November 1, 2026
Example. Cospectral graphs with the same selector [fdip-005H]AGENTDRAFTED
- November 1, 2026
There are selected backgrounds related by the orthogonal comparison with no signed graph arrow. On vertices \(\{0,1,2,3,4,5\}\), take simple graphs with unit weights and the following unordered edges: \[\begin {aligned} E_A&=\{02,03,04,05,14,15,23\},\\ E_B&=\{02,04,05,12,14,15,23\}. \end {aligned}\] Orient each edge from its lower to its higher endpoint, choose \(m=1\), and in both cases choose \(P=\mathbf 1\mathbf 1^T/6\), the projector onto the constant line. Both graphs are connected. Their degree multisets are \((4,2,2,2,2,2)\) and \((3,3,3,2,2,1)\), so even their unoriented incidence presentations are not isomorphic.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For graph \(A\), the differences on the twin pairs \(\{2,3\}\) and \(\{4,5\}\) have Laplacian eigenvalues \(3\) and \(2\). On fields constant on the cells \(\{0\}\), \(\{1\}\), \(\{2,3\}\), \(\{4,5\}\), in that order, the remaining matrix is \[M_A=\begin {pmatrix} 4&0&-2&-2\\0&2&0&-2\\-1&0&1&0\\-1&-1&0&2 \end {pmatrix}.\] For graph \(B\), use twin differences on \(\{0,1\}\) and \(\{4,5\}\), again of eigenvalues \(3\) and \(2\). On cells \(\{0,1\}\), \(\{2\}\), \(\{3\}\), \(\{4,5\}\), in that order, the matrix is \[M_B=\begin {pmatrix} 3&-1&0&-2\\-2&3&-1&0\\0&-1&1&0\\-2&0&0&2 \end {pmatrix}.\] These are cell-value coordinates, so the displayed quotient matrices need not be symmetric. In each case expansion gives \[\det (tI-M_A)=\det (tI-M_B)=t(t-3)(t^2-6t+4).\] Together with the two difference eigenvectors, this proves the common Laplacian spectrum \(0,2,3,3,3-\sqrt 5,3+\sqrt 5\). Choose orthonormal eigenbases with the same normalized constant vector \(\mathbf 1 / \sqrt 6\) first, and map one basis to the other. The resulting \(O\) conjugates \(L_A\) to \(L_B\), hence also \(Q_A=L_A+I\) to \(Q_B=L_B+I\). It fixes the constant line and therefore transports \(P\) as well. This proves the selected comparison. The degree multisets exclude every signed graph arrow.
Proposition. Graph and orthogonal stabilizers [fdip-005I]AGENTDRAFTED
- November 1, 2026
Proposition. Graph and orthogonal stabilizers [fdip-005I]AGENTDRAFTED
- November 1, 2026
The stabilizers also distinguish the two notions. For the alternating four-cycle family, with weights \((a,b,a,b)\), \(m>0\), and \(R=\{0,2\}\), the stabilizer of \((Q,P_R)\) in \(O(4)\) is \((C_2)^2\) if \(a\ne b\), and \((C_2)^3\) if \(a=b\). The signed graph stabilizers are respectively \(C_2\) and \(C_2\times C_2\). By contrast, the orthogonal stabilizer of \(Q\) alone is continuous when \(a=b\); it contains \(O(2)\) on the repeated eigenspace.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Use the orthonormal eigenvectors \[\begin {aligned} u_0&=(1,1,1,1)/2,&u_3&=(1,-1,1,-1)/2,\\ u_1&=(1,1,-1,-1)/2,&u_2&=(1,-1,-1,1)/2. \end {aligned}\] Their eigenvalues are \(m^2,m^2+2a+2b,m^2+2b,m^2+2a\), respectively. In the ordered pairs \((u_0,u_3)\) and \((u_1,u_2)\), \(P_R\) has the same block \(\frac 12\begin {pmatrix}1&1\\1&1\end {pmatrix}\). If \(a\ne b\), all 4 eigenvalues are distinct, so an orthogonal commuter of \(Q\) chooses one sign on each eigenline. Commuting with \(P_R\) makes the signs equal within each pair, leaving two independent signs. If \(a=b\), the first pair still shares one sign. On \(\operatorname {span}(u_1,u_2)\), an orthogonal commuter must preserve the two lines spanned by \(u_1+u_2\) and \(u_1-u_2\), leaving two further signs. This proves the orthogonal counts.
For a signed graph symmetry \(r^ks^\epsilon \) with \(r(i)=i+1\), \(s(i)=-i\), the opposite set is preserved iff \(k\) is even. When \(a\ne b\), weight preservation additionally requires \(k+\epsilon \) even. Thus only \(1,r^2\) remain; when \(a=b\), \(1,r^2,s,r^2s\) remain. These are all possibilities because the underlying simple-cycle automorphism group is \(D_4\), as in Example [fdip-000X].
Definition. The base and its retained-law fibers [fdip-005E]AGENTDRAFTED
- November 1, 2026
Definition. The base and its retained-law fibers [fdip-005E]AGENTDRAFTED
- November 1, 2026
Fix an incidence presentation \(\Pi =(V,E,s,h)\), with \(|V|\ge 2\). Its parameter set and selector set are \[\begin {aligned} \operatorname {Par}_{\Pi }&=\mathbb R_{>0}^E\times \mathbb R_{>0},\\ \operatorname {Sel}_V&=\{P:P^2=P=P^*,\ 0<\operatorname {rank}P<|V|\},\\ \mathcal B_\Pi &=\operatorname {Par}_\Pi \times \operatorname {Sel}_V. \end {aligned}\] The counting metric is fixed. Each rank component of \(\operatorname {Sel}_V\) identifies with the real Grassmannian \(\operatorname {Gr}_r(H)\), the set of \(r\)-dimensional subspaces of \(H\), by \(P\mapsto \operatorname {im}P\); the unique orthogonal projector gives the inverse identification. No topology or smooth structure is needed for the following groupoid description.
Only the directed automorphism group \(\operatorname {Aut}(\Pi )\) acts on this fixed-presentation set. For \(g=(p,q)\), let \(U_g\delta _v=\delta _{p(v)}\) and put \[g(w,m,P)=(w\circ q^{-1},m,U_gPU_g^{-1}).\] Its action groupoid \(\operatorname {Aut}(\Pi )\ltimes \mathcal B_\Pi \) is the full subgroupoid of \(\mathsf {Bg}\) on backgrounds whose presentation is exactly \(\Pi \): in both cases arrows are precisely the same graph automorphisms satisfying the parameter equations. Replacing directed automorphisms by signed endpoint automorphisms gives the corresponding full subgroupoid of \(\mathsf {Bg}^{\pm }\).
To allow arrows between presentations, take \(\mathcal B=\coprod _\Pi \mathcal B_\Pi \), over a fixed set of finite labelled presentations, with \(\mathsf {Bg}\) as its groupoid of arrows. For example one may use finite subsets of a fixed countable universe as carriers; every finite presentation has an isomorphic labelled representative. There is no single action of \(\operatorname {Aut}(\Pi )\) on all presentations.
The selected-structure map is \[\sigma :\mathcal B\longrightarrow \operatorname {Ob}(\mathcal Q),\qquad \sigma (b)=(X,S_P),\quad X=\operatorname {im}P,\] where \(\mathcal Q\) is the groupoid of positive-dimensional real Euclidean spaces with positive self-adjoint precisions and isometric precision-intertwining arrows. More precisely, the displayed object map extends to a functor \(\mathsf {Bg}\to \mathcal Q\), or \(\mathsf {Bg}^{\pm }\to \mathcal Q\), by sending an arrow to \(U|_X\). The transport identities and ordinary restriction of composites prove functoriality. The symbol \(\sigma \) denotes this assignment, whereas \(P:H\to H\) is the field-space projector.
The retained-law fiber over \(b\) is the probability space \[\mathcal F_b=(X,\mathcal B(X),\nu _b),\qquad \nu _b=N_X(0,S_P^{-1}).\] Here \(\mathcal B(X)\) is the Borel sigma-algebra. Arrows transport these fibers by measure-preserving isometries and transport observables by pullback. Thus a fiber is a specified law on a specified space, rather than a bare covariance matrix. If an interaction is additionally supplied, its induced retained vertices require that further data; they are not part of the present Gaussian tuple.
Forgetting \(P\) gives the unselected weighted incidence data \((\Pi ,w,m)\) and their full law \(\mu _Q\). It does not by itself give a coordinate background, which also requires a retained subset \(R\). Choosing \(P=P_R\) recovers that background and its Schur marginal. Equivalence here means isomorphism in the chosen graph groupoid; the orthogonal comparison is coarser. For a different operation, the supplied cycle scaling of the circle comparison is a limit of models, not a graph arrow.
Example. Three selectors on the same four-cycle [fdip-005F]AGENTDRAFTED
- November 1, 2026
Example. Three selectors on the same four-cycle [fdip-005F]AGENTDRAFTED
- November 1, 2026
Take the unit four-cycle, \(m=1\), and vertex order \((0,1,2,3)\). Its full precision and covariance are \[\begin {aligned} Q&=\begin {pmatrix} 3&-1&0&-1\\-1&3&-1&0\\0&-1&3&-1\\-1&0&-1&3 \end {pmatrix},\\ G&=\frac 1{15}\begin {pmatrix} 7&3&2&3\\3&7&3&2\\2&3&7&3\\3&2&3&7 \end {pmatrix}. \end {aligned}\] Multiplication gives \(QG=I\); the full spectrum is \(1,3,3,5\). The graph and full law stay fixed in all three selections below.
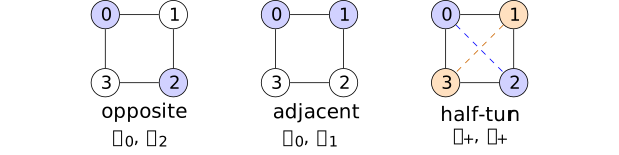
In the first two panels, filled vertices are retained coordinates. In the third, the paired colors and dashed diagonals indicate the normalized sums \(x_+=(\phi _0+\phi _2)/\sqrt 2\) and \(y_+=(\phi _1+\phi _3)/\sqrt 2\); the diagonals are pairing guides, not added graph edges. All three observations have rank two.
For \(R=\{0,2\}\), use the orthonormal retained basis \((\delta _0,\delta _2)\). Compressing \(G\) and inverting gives \[\begin {aligned} C_{\mathrm {opp}}&=\frac 1{15}\begin {pmatrix}7&2\\2&7\end {pmatrix},\\ S_{\mathrm {opp}}&=\frac 13\begin {pmatrix}7&-2\\-2&7\end {pmatrix}. \end {aligned}\] The sum and difference vectors have precision eigenvalues \(5/3,3\); their product is \(\det S_{\mathrm {opp}}=5\). This is the opposite-vertex marginal.
For \(R=\{0,1\}\), use \((\delta _0,\delta _1)\). The same operation yields \[\begin {aligned} C_{\mathrm {adj}}&=\frac 1{15}\begin {pmatrix}7&3\\3&7\end {pmatrix},\\ S_{\mathrm {adj}}&=\frac 18\begin {pmatrix}21&-9\\-9&21\end {pmatrix}. \end {aligned}\] Its sum and difference eigenvalues are \(3/2,15/4\), with \(\det S_{\mathrm {adj}}=45/8\). This recovers the fixed-label counterexample as a change of selector.
Finally let \(H_2\delta _i=\delta _{i+2}\) be the half-turn and \(P_+=(I+H_2)/2\). In the orthonormal basis \[v_0=(\delta _0+\delta _2)/\sqrt 2,\qquad v_1=(\delta _1+\delta _3)/\sqrt 2\] of its image, the positive sector has \[\begin {aligned} C_+&=\frac 15\begin {pmatrix}3&2\\2&3\end {pmatrix},\\ S_+&=\begin {pmatrix}3&-2\\-2&3\end {pmatrix}. \end {aligned}\] Indeed \(Qv_0=3v_0-2v_1\) and \(Qv_1=-2v_0+3v_1\), so this space is \(Q\)-invariant and the retained precision is the restriction. Its eigenvalues are \(1,5\), with determinant \(5\). The coordinates are normalized sums \((\phi _0+\phi _2)/\sqrt 2\), \((\phi _1+\phi _3)/\sqrt 2\), not the values of two retained vertices.
All three laws follow from the selected-law theorem with the displayed basis choices. Equal rank, or even the shared determinant \(5\) of the first and third examples, does not force equal retained spectra.
Example. Quaternion and coordinate selectors [fdip-005G]AGENTDRAFTED
- November 1, 2026
Example. Quaternion and coordinate selectors [fdip-005G]AGENTDRAFTED
- November 1, 2026
Let \(\Gamma =Q_8=\{\pm 1,\pm i,\pm j,\pm k\}\) and take the simple undirected Cayley graph with edges \(\{g,gs\}\), \(s\in \{\pm i,\pm j\}\), counted once each. Give each edge weight one, choose any orientation, and set \(m=1\). The two parts \[A=\{\pm 1,\pm k\},\qquad B=\{\pm i,\pm j\}\] give \(K_{4,4}\): every vertex in one part has the 4 distinct vertices of the other as its neighbors. In part order, \[L=\begin {pmatrix}4I_4&-J_4\\-J_4&4I_4\end {pmatrix}, \qquad Q=L+I_8,\] where \(J_4\) is the all-ones matrix. The two constant-on-part vectors give Laplacian eigenvalues \(0,8\); the two partwise zero-sum spaces give eigenvalue \(4\), of total multiplicity 6.
Left multiplication gives a signed graph action \(\rho \) on \(\mathbb R^{Q_8}\), independent of the arbitrary edge orientations. For the central involution \(z=-1\), put \[e_-=(1-[z])/2\in \mathbb R[Q_8],\qquad P_-=\rho (e_-)=(I-\rho (z))/2.\] Since \(z^2=1\) and \(z^{-1}=z\), this is a self-adjoint idempotent. Its image is the four-dimensional space of fields \(f(-g)=-f(g)\). The group-algebra decomposition \(\mathbb R[Q_8]\cong \mathbb R^4\times \mathbb H\) in Proposition [fgap-001B] sends \(e_-\) to \((0,1)\): each real character takes \(z\) to \(1\), while the quaternionic realization takes it to \(-1\). Thus this selector retains precisely the quaternion factor in the regular module, without assigning it a physical interpretation.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
An odd field has zero sum on each of \(A,B\), since each part is a union of pairs \(\{g,-g\}\). Therefore \(J_4\) kills its restriction to either part, and the displayed Laplacian gives \(Lf=4f\). An orthonormal basis is \((\delta _g-\delta _{-g})/\sqrt 2\) for \(g=1,i,j,k\). Hence the selected precision is \[S_-=5I_4,\qquad C_-=I_4/5.\] Equivalently, the two neighbor contributions indexed by \(s,-s\) cancel on an odd field. The positive mass supplies the shift from \(4\) to \(5\).
Compare the coordinate selector on the subgroup \(R=\langle i\rangle =\{1,-1,i,-i\}\), which retains two vertices from each part. In the full graph, decompose fields into the two constant-on-part lines and the two partwise zero-sum spaces. On the normalized part constants, the precision and covariance are \[\begin {pmatrix}5&-4\\-4&5\end {pmatrix},\qquad \frac 19\begin {pmatrix}5&4\\4&5\end {pmatrix};\] on the zero-sum spaces the covariance is \(1/5\). It follows that full covariance entries are \(13/45\) on the diagonal, \(4/45\) between distinct vertices in the same part, and \(1/9\) between parts. For example the first entry is \((1-1/4)/5+(5/9)/4=13/45\).
In retained order \((1,-1,i,-i)\), compression therefore gives \[C_R=\frac 1{45}\begin {pmatrix} 13&4&5&5\\4&13&5&5\\5&5&13&4\\5&5&4&13 \end {pmatrix}.\] The two within-part difference vectors have covariance eigenvalue \((13-4)/45=1/5\). On normalized retained part constants the covariance block is \(\frac 1{45}\begin {pmatrix}17&10\\10&17\end {pmatrix}\), with eigenvalues \(3/5,7/45\). Inversion gives the retained precision spectrum \[\operatorname {spec}(S_R)=\{5/3,5,5,45/7\}.\] It differs from \(\{5,5,5,5\}\) for the quaternion selector despite equal rank and the same full background precision.
The chosen \(Q_8\) action is auxiliary data used to construct \(P_-\); it is not another slot of the selected tuple. Indeed the underlying graph has \(2(4!)^2=1152\) automorphisms: its connected bipartition is unique up to exchange, and every permutation within either part, as well as their exchange, preserves all edges. The selected-background groupoid remembers the graph and the resulting projector, not a named subgroup of this automorphism group. Remembering the action would require an enhanced tuple and arrows intertwining that action.
Proposition. Invariants of a selected background [fdip-005J]AGENTDRAFTED
- November 1, 2026
Proposition. Invariants of a selected background [fdip-005J]AGENTDRAFTED
- November 1, 2026
For a selected background, put \(X=\operatorname {im}P\). The following are invariants of its orthogonal comparison class:
- the spectrum of \(Q\), with multiplicities, and the rank of \(P\);
- the spectrum of \(S_P\), hence its determinant and trace;
- for each eigenvalue \(\lambda \) of \(Q\), the principal angles between \(X\) and \(E_\lambda =\ker (Q-\lambda I)\).
Here principal angles are defined by taking orthonormal inclusion matrices \(B_X,B_\lambda \) and the \(\min (\dim X,\dim E_\lambda )\) singular values of \(B_X^*B_\lambda \). These numbers lie in \([0,1]\); their arccosines, in increasing order, are the angles. This definition includes zero singular values and uses the entire eigenspace when \(\lambda \) is repeated. It is independent of the two orthonormal bases.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
If \(Q'=OQO^{-1}\) and \(P'=OPO^{-1}\), then \(O(X)=X'\) and \(O(E_\lambda )=E'_\lambda \). Choosing the transported bases leaves \(B_X^*B_\lambda \) unchanged; changing either basis multiplies this matrix on the left or right by an orthogonal matrix, which does not change its singular values. These are at most one because both inclusions and orthogonal projections have operator norm at most one. Conjugation gives the spectrum of \(Q\) and rank of \(P\). The selected-law transport gives \(S_{P'}=(O|_X)S_P(O|_X)^{-1}\), proving the remaining claims.
These are consequently invariants of both graph groupoids \(\mathsf {Bg}\) and \(\mathsf {Bg}^{\pm }\). There is additional incidence information: the isomorphism class of the weighted incidence presentation with its selector, and the order of its finite automorphism group, are invariants in the chosen graph groupoid. Indeed, an arrow \(g:b\to b'\) induces the group isomorphism \(\alpha \mapsto g\alpha g^{-1}\) of automorphism groups. The directed and signed groups are different choices here; \(|\operatorname {Aut}_{\mathsf {Bg}}(b)|\) is not being asserted invariant under an arbitrary signed arrow.
The cospectral pair has an orthogonal comparison but no graph arrow. Thus even all the listed spectral and angle invariants cannot recover incidence. No completeness claim for invariants of the pair \((Q,P)\) under \(O(H)\) is made.
TauCeti's TauCeti.cosPrincipalAngles defines
the singular values of the overlap operator of two finite
orthonormal families as a nonincreasing sequence padded by zeros.
Taking its first \(\min (\dim X,\dim E_\lambda )\) values and then
arccosines gives the convention above. Its
TauCeti.cosPrincipalAngles_le_one supplies the
upper bound; the background-conjugacy and incidence claims are
the separate arguments here.
Theorem. Three inequivalent selectors and their observables [fdip-005K]AGENTDRAFTED
- November 1, 2026
Theorem. Three inequivalent selectors and their observables [fdip-005K]AGENTDRAFTED
- November 1, 2026
On the unit four-cycle with \(m=1\), the opposite, adjacent and positive half-turn selectors are pairwise inequivalent under the orthogonal comparison. Consequently no directed or signed graph arrow identifies any pair. Their retained precisions have the following invariants:
\[\begin {array}{c|c|c|c} \text {selector}&\operatorname {spec}S_P&\det S_P&\operatorname {tr}S_P\\\hline \text {opposite}&\{5/3,3\}&5&14/3\\ \text {adjacent}&\{3/2,15/4\}&45/8&21/4\\ \text {half-turn}&\{1,5\}&5&6. \end {array}\]
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The three two-by-two precisions and their eigenvectors are computed in Example [fdip-005F]. Their distinct spectra separate them by the invariance proposition. Products and sums of the eigenvalues give the displayed determinants and traces.
The intrinsic squared-norm observable has expectation \[\mathbb E_{\mu _Q}\|P\phi \|^2 =\mathbb E_{\nu _b}\|x\|^2 =\operatorname {tr}_X C_P =\operatorname {tr}_H(PG).\] Indeed, in an orthonormal basis of \(X\) the squared norm is the sum of squares of coordinates, each with variance equal to the corresponding diagonal covariance entry. Since \(C_P=(PGP)|_X\) and \(P^2=P\), cyclicity of the finite-dimensional trace gives the last equality. In the same order as the table, \[\mathbb E\|P\phi \|^2=\frac {14}{15},\quad \frac {14}{15},\quad \frac 65.\] The reciprocal eigenvalues give these values. Thus neither \(\det S_P\) nor this covariance trace alone separates all three selectors. In particular the equal covariance traces of the first two do not mean equal precision traces.
For the two coordinate selectors, named coordinate observations also distinguish the laws. The full covariance in Example [fdip-005F] gives \[\begin {aligned} \frac {\langle \phi _0\phi _2\rangle }{\langle \phi _0^2\rangle } &=\frac 27&&\text {(opposite)},\\ \frac {\langle \phi _0\phi _1\rangle }{\langle \phi _0^2\rangle } &=\frac 37&&\text {(adjacent)}. \end {aligned}\] The marginal expectation identity makes these the corresponding retained expectations. They refer to the stated vertex coordinates; unlike the spectrum and squared norm, such coordinate ratios are not invariants under arbitrary orthogonal changes of retained basis.
Corollary. The unselected graph does not determine the retained law [fdip-005L]AGENTDRAFTED
- November 1, 2026
Corollary. The unselected graph does not determine the retained law [fdip-005L]AGENTDRAFTED
- November 1, 2026
On selected backgrounds, the retained-precision spectrum does not factor through the isomorphism class of the unselected weighted incidence data \((\Pi ,w,m)\). In particular, that unselected class does not determine the retained Gaussian law up to a precision-intertwining isometry. This holds for either the directed or the signed graph groupoid.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Take isomorphism classes in the chosen groupoid and apply the forgetful map that removes \(P\). The retained spectrum is well-defined on these classes by Proposition [fdip-005J]. The three four-cycle selections have exactly the same incidence, weights and mass, so they belong to one fiber of the forgetful map, but their retained spectra differ. The fiber-constancy criterion therefore rules out a factorization through the unselected class. An isometric intertwiner of retained precisions would preserve their spectra, so it cannot identify these retained laws.
This obstruction concerns forgetting the selector, not a failure of the selected-law formula: \((\Pi ,w,m,P)\) does determine \(\nu _b\). In the other direction, the weighted-cycle comparison fixes the coordinate selector and mass while changing the weights; its retained covariance changes. Together the examples show why both the weighted incidence data and the selector must be retained to specify the observed law. They supply no physical rule for how either datum varies.
Theorem. When a marginal precision is a restriction [fdip-005M]AGENTDRAFTED
- November 1, 2026
Theorem. When a marginal precision is a restriction [fdip-005M]AGENTDRAFTED
- November 1, 2026
Let \(Q>0\) be self-adjoint on a finite-dimensional real Euclidean space \(H\) and let \(P\) be an orthogonal projector. Assume its image \(X\) and kernel \(Y\) are nonzero. In \(H=X\oplus Y\), write \[Q=\begin {pmatrix}A&K\\K^*&D\end {pmatrix},\qquad D>0.\] The selected precision obeys \[S_P=A-KD^{-1}K^*\preceq A.\] Here \(A=PQ|_X\) is the compression, and \(T\preceq A\) means that \(\langle x,(A-T)x\rangle \ge 0\) for every \(x\in X\). The following conditions are equivalent: \[\begin {aligned} S_P=A&\quad \Longleftrightarrow \quad K=0\\ &\quad \Longleftrightarrow \quad QX\subseteq X \quad \Longleftrightarrow \quad PQ=QP. \end {aligned}\] In this case \(A=Q|_X\); call the selector restricting. Otherwise it induces a different precision through elimination of the complement.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The Schur formula is proved in Theorem [fdip-005B]. Its difference from the compression satisfies \[\langle x,(A-S_P)x\rangle =\|D^{-1/2}K^*x\|^2\ge 0.\] It vanishes for all \(x\) exactly when \(K^*=0\), since \(D^{-1/2}\) is invertible. The \(Y\)-component of \(Q(x,0)\) is \(K^*x\), so the same condition is \(QX\subseteq X\). Self-adjointness then makes \(Y=X^\perp \) invariant as well: \(\langle Qy,x\rangle =\langle y,Qx\rangle =0\). The resulting block diagonal matrix commutes with \(P\); conversely \(PQ=QP\) carries its image to itself.
When \(K\ne 0\), the positive semidefinite difference \(A-S_P\) is nonzero, so the quadratic form decreases in some direction. It need not be positive definite: some directions may have zero loss. The assertion is a Loewner inequality with the stated equality criterion, not a strict inequality in every direction.
For a positive-weight graph and a coordinate selector \(P_R\), \(K\) consists of the entries of \(Q\) between \(R\) and its complement. For distinct vertices these are minus the sum of weights of edges joining them; orientation does not affect the sum. All summands are positive. Hence \(K=0\) exactly when no edge joins \(R\) to its complement. In a connected graph every nonempty proper coordinate selector therefore induces a different precision. In particular, the retained vertices in cycle decimation are stable under the retained cyclic action, but this symmetry does not make their span \(Q\)-invariant.
In orthonormal coordinates, Mathlib's
Matrix.PosDef.inv gives positivity of \(D^{-1}\).
The congruence lemma
Matrix.PosSemidef.mul_mul_conjTranspose_same,
with its positive semidefinite matrix set to \(D^{-1}\) and its
rectangular matrix set to \(K\), gives \(KD^{-1}K^*\succeq 0\).
These declarations support the positivity steps. The equality
criterion, subspace equivalences and graph specialization are
proved above.
Corollary. Which symmetry selectors restrict [fdip-005N]AGENTDRAFTED
- November 1, 2026
Corollary. Which symmetry selectors restrict [fdip-005N]AGENTDRAFTED
- November 1, 2026
Let a finite group \(\Gamma \) act orthogonally on a finite-dimensional real Euclidean space \(H\), and let \(Q>0\) be self-adjoint and \(\Gamma \)-equivariant. Two constructions of symmetry selectors have different criteria.
- For a self-adjoint idempotent \(e\in \mathbb R[\Gamma ]\), the selector \(P=\rho (e)\) restricts whenever its rank is nonzero and proper. Its image need not be a \(\Gamma \)-subrepresentation.
- A nonzero proper \(\Gamma \)-subrepresentation \(X\) restricts precisely when its multiplicity subspace in every real isotypic block is invariant under the corresponding Hermitian precision matrix \(Q_\Xi \).
Here is the precise multiplicity convention. Use the real commutant and the right-scalar column coordinates. For \(D_\Xi =\operatorname {End}_\Gamma (W_\Xi )\) and \(r_\Xi =\dim _{D_\Xi }W_\Xi \), represent \(H_\Xi \) by \(r_\Xi \) columns in \(D_\Xi ^{m_\Xi }\); matrices act on each column by left multiplication. There is a right \(D_\Xi \)-subspace \(U_\Xi \subseteq D_\Xi ^{m_\Xi }\) such that \[X\cap H_\Xi \cong \{(z_1,\ldots ,z_{r_\Xi }):z_a\in U_\Xi \}.\] The criterion is \[Q_\Xi U_\Xi \subseteq U_\Xi \qquad \text {for every }\Xi .\] Equivalently, each \(U_\Xi \) has a \(D_\Xi \)-basis of \(Q_\Xi \)-eigenvectors. Repeated eigenvalues allow proper subspaces of an eigenspace; whole eigenspaces need not be selected.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Equivariance makes \(Q\) commute with every \(\rho (g)\), hence with \(\rho (e)\). The restriction criterion proves the first assertion. Centrality is not needed for this commutation; it would additionally make \(\rho (e)\) commute with the group action.
For a subrepresentation \(X\), both \(X\) and \(X^\perp \) are \(\Gamma \)-stable, so its orthogonal projector belongs to the commutant. By Theorem [fdip-004Z] it is represented by Hermitian idempotents \(p_\Xi \in M_{m_\Xi }(D_\Xi )\). In the stated column coordinates its image has exactly the displayed form with \(U_\Xi =\operatorname {im}p_\Xi \). Conversely a right \(D_\Xi \)-subspace has an orthogonal projector commuting with right scalar multiplication: its real orthogonal complement is right-scalar stable, since multiplication by each unit scalar is orthogonal and preserves the subspace. Thus that projector is a matrix over \(D_\Xi \); the commutant identification gives the corresponding subrepresentation.
The matrix \(Q_\Xi \) acts on every column, so \(QX\subseteq X\) is exactly the displayed invariance condition. If it holds, self-adjointness preserves the orthogonal complement too. The Hermitian spectral argument of Corollary [fdip-0050] applies to the restriction on \(U_\Xi \): a real eigenvector generates a right \(D_\Xi \)-line of eigenvectors, its orthogonal complement is invariant, and induction gives a \(D_\Xi \)-orthonormal eigenbasis. Conversely a span of eigenvectors is invariant, since their eigenvalues are real and the matrix is right-linear. Apply Theorem [fdip-005M] to finish.
In a multiplicity-free representation every \(m_\Xi =1\), and a right \(D_\Xi \)-subspace of \(D_\Xi \) is either zero or all of it. Thus every nonzero proper subrepresentation restricts. At higher multiplicity, group stability alone does not suffice, as the prism line shows.
Example. A stable prism line and a partial eigenspace [fdip-005O]AGENTDRAFTED
- November 1, 2026
Example. A stable prism line and a partial eigenspace [fdip-005O]AGENTDRAFTED
- November 1, 2026
In the twisted prism, let \(e_u\) and \(e_l\) be the normalized constant vectors on the upper and lower triangles. The group \(\Gamma =C_3\) fixes each, and its trivial isotypic block has multiplicity two. In this orthonormal basis the precision and covariance are \[\begin {aligned} Q_{\mathrm {triv}} &=\begin {pmatrix}5/2&-3/2\\-3/2&5/2\end {pmatrix},\\ Q_{\mathrm {triv}}^{-1} &=\begin {pmatrix}5/8&3/8\\3/8&5/8\end {pmatrix}. \end {aligned}\] Their product is the identity; the determinant of the first is \(4\). The other isotypic block is orthogonal and uncoupled.
Select \(X=\mathbb R e_u\), the line of fields constant on the upper triangle and zero on the lower one. This line is \(\Gamma \)-stable, but \(Qe_u=(5/2)e_u-(3/2)e_l\notin X\). Its compressed covariance is \(5/8\), so \[S_P=\frac 85,\qquad PQ|_X=\frac 52.\] Equivalently, eliminating the lower constant line gives \[\frac 52-\frac {(3/2)^2}{5/2}=\frac 85.\] Thus this subrepresentation induces a different precision. By contrast, the lines spanned by \(e_u+e_l\) and \(e_u-e_l\) have precision eigenvalues \(1\) and \(4\), respectively. Their orthogonal selectors restrict, with retained precisions \(1\) and \(4\). This directly verifies the multiplicity-subspace criterion.
The word eigenvectors in that criterion cannot be replaced by whole eigenspaces. Let the trivial group act on the unit four-cycle. The precision has eigenvalue \(3\) on the two-dimensional space spanned by \[v=(1,0,-1,0),\qquad w=(0,1,0,-1).\] Direct multiplication gives \(Qv=3v\) and \(Qw=3w\). The selector onto \(\mathbb R v\) is proper within this eigenspace and restricts, with \(S_P=3\) in the unit coordinate \(v/\sqrt 2\). Every subspace is stable under the trivial group, but only \(Q\)-invariant ones meet the restriction criterion.
Remark. Isotropy pieces of the background parameter set [fdip-005P]AGENTDRAFTED
- November 1, 2026
Remark. Isotropy pieces of the background parameter set [fdip-005P]AGENTDRAFTED
- November 1, 2026
For a fixed incidence presentation \(\Pi \), let \(K_\Pi \) be its finite group of signed endpoint automorphisms, acting on the parameter set \(\mathcal B_\Pi \). The isotropy group at \(b\) is \((K_\Pi )_b=\{g:g b=b\}\). Partition \(\mathcal B_\Pi \) by the conjugacy class in \(K_\Pi \) of this stabilizer. These are its isotropy pieces. If \(b'=g b\), then \((K_\Pi )_{b'}=g(K_\Pi )_b g^{-1}\), so an orbit stays inside one piece. Between different presentations, graph arrows still identify the automorphism groups, without placing all of them inside one common acting group.
Write \(b_{a,b}\) for the alternating four-cycle with positive weights \((a,b,a,b)\), fixed \(m>0\), and retained pair \(\{0,2\}\). The signed stabilizer calculation gives \[\operatorname {Aut}_{\mathsf {Bg}^{\pm }}(b_{a,b}) \cong \begin {cases} C_2&a\ne b,\\ C_2\times C_2&a=b. \end {cases}\] This is a change of isotropy at equal weights. In the directed groupoid the uniformly oriented unit cycle admits only rotations; preserving \(\{0,2\}\) leaves the identity and half-turn, so its stabilizer is \(C_2\). Reflections belong to the larger signed convention.
The orthogonal stabilizers of the same pair \((Q,P_R)\) are \((C_2)^2\) and \((C_2)^3\), as proved in Proposition [fdip-005I]. They describe a different comparison and do not define the graph isotropy pieces above. Here strata can mean only this set-level partition by isotropy type. No smooth stratification, analytic singularity or physical phase transition follows from it. Those further interpretations require additional structure and arguments.
Induced action and interactions [fdip-005Q]AGENTDRAFTED
- November 1, 2026
Induced action and interactions [fdip-005Q]AGENTDRAFTED
- November 1, 2026
Integrating all fields produces a scalar that depends on the supplied graph weights and mass. Its derivatives measure fluctuations of edge differences; its determinant also counts rooted forests. These are two descriptions of the same finite Gaussian normalization. The selected-background comparison distinguishes changes of the supplied data from coordinate changes. In this full-field integral the selector plays no role.
The four-cycle makes the derivative and forest formulas explicit. The circle example then keeps the finite determinant and its chosen normalization visible while taking a mesh limit. No continuum measure or canonical infinite-dimensional determinant is needed for that limit.
Keeping a selected field and integrating its complement instead produces an interaction on the retained space. Conditional means and covariances determine its formal coefficients. Their transport follows the same background arrow, provided it also transports the supplied interaction. A quartic cycle example shows how graph weights and the selector enter the induced vertices, without asserting convergence of the perturbation series.
Definition. The Gaussian induced action [fdip-005R]AGENTDRAFTED
- November 1, 2026
Definition. The Gaussian induced action [fdip-005R]AGENTDRAFTED
- November 1, 2026
Fix a finite nonempty vertex set \(V\), with \(n=|V|\), and a finite set \(E\) of labelled edges with source and head maps. Orientations are auxiliary. In the counting metric on \(\mathbb R^V\), put \(d_e=\delta _{h(e)}-\delta _{s(e)}\). For weights \(w_e\ge 0\) and mass \(m>0\), write \[L_w=\sum _{e\in E}w_e d_ed_e^T,\qquad Q=L_w+m^2I,\qquad G=Q^{-1}.\] A zero weight means the corresponding edge is deleted. Parallel labels remain distinct, and a loop has \(d_e=0\). Thus the boundary faces of this weight orthant describe subgraphs, extending the positive-weight background convention.
The Gaussian induced action, relative to counting-metric Lebesgue measure, is \[\mathcal W(w,m)=\frac 12\log \det Q.\] The Gaussian normalizer gives \[Z(w,m)=\int _{\mathbb R^V}e^{-\phi ^TQ\phi /2}\,d\phi =(2\pi )^{n/2}(\det Q)^{-1/2},\] so \(-\log Z=\mathcal W-(n/2)\log (2\pi )\). This scalar is invariant under graph relabeling and orthogonal conjugation of \(Q\). It does not by itself retain all graph or selector data.
For fixed \(m>0\), differentiation in the weights means differentiation of the smooth extension to \[\mathcal U_m=\{w\in \mathbb R^E:L_w+m^2I>0\}.\] This open convex set contains the nonnegative orthant. For \(w_e\ge 0\) and \(x\ne 0\), indeed, \[x^TQx=\sum _e w_e(d_e^Tx)^2+m^2\|x\|^2>0.\] In particular the formulas below remain meaningful at deleted edges, even though only nonnegative weights are interpreted as graph conductances.
Theorem. An edge derivative is half its variance [fdip-005S]AGENTDRAFTED
- November 1, 2026
Theorem. An edge derivative is half its variance [fdip-005S]AGENTDRAFTED
- November 1, 2026
For the induced action, with \(m>0\) fixed, \[\frac {\partial \mathcal W}{\partial w_e} =\frac 12 d_e^TGd_e =\frac 12\mathbb E[(\phi _{h(e)}-\phi _{s(e)})^2],\] where \(\phi \sim N(0,G)\). Each derivative is nonnegative.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For any square matrix \(B\), multilinearity of the determinant gives \(\det (I+tB)=1+t\operatorname {tr}B+O(t^2)\): the linear terms select one diagonal entry of \(tB\), and all higher terms use at least two entries of \(tB\). Factoring an invertible \(Q\) yields \[\det (Q+tA)=\det Q\det (I+tQ^{-1}A).\] When \(Q>0\) and \(A\) is symmetric, the perturbed matrix is positive for sufficiently small \(|t|\). Differentiating its real logarithm therefore gives \[\left .\frac {d}{dt}\log \det (Q+tA)\right |_{t=0} =\operatorname {tr}(Q^{-1}A).\] Set \(A=d_ed_e^T\); cyclicity of trace gives \(\operatorname {tr}(Gd_ed_e^T)=d_e^TGd_e\). Finally the covariance identity says \(\mathbb E[(d_e^T\phi )^2]=d_e^TGd_e\ge 0\).
The matrix differential is the log-determinant gradient in
[boyd2004convex, Appendix A.4.1, pp. 641-642].
TauCeti's Matrix.fderiv_det_apply states
\(D\det (Q)[A]=\det (Q)\operatorname {tr}(Q^{-1}A)\) for a finite
matrix over a complete nontrivially normed field whose determinant
is a unit. Over \(\mathbb R\), positivity supplies this hypothesis.
It supports the determinant derivative; the logarithm, edge direction
and Gaussian interpretation are the steps proved here.
Theorem. Concavity and covariance of squared edge differences [fdip-005T]AGENTDRAFTED
- November 1, 2026
Theorem. Concavity and covariance of squared edge differences [fdip-005T]AGENTDRAFTED
- November 1, 2026
On the open set \(\mathcal U_m\) of Definition [fdip-005R], \[\frac {\partial ^2\mathcal W}{\partial w_e\partial w_f} =-\frac 12(d_e^TGd_f)^2.\] The induced action is concave, including on the nonnegative weight orthant. For the corresponding centered Gaussian field, \[\operatorname {Cov}((d_e^T\phi )^2,(d_f^T\phi )^2) =2(d_e^TGd_f)^2,\] so the Hessian is minus one quarter of this covariance matrix.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Differentiating \(QG=I\) in weight \(w_f\) gives \(\partial _fG=-Gd_fd_f^TG\). Substitute this into Theorem [fdip-005S]; symmetry of \(G\) gives the Hessian entry. For a real weight direction \(a=(a_e)\), set \(A=\sum _e a_e d_ed_e^T\). Its second directional derivative is \[D^2\mathcal W[a,a] =-\frac 12\operatorname {tr}(GAGA) =-\frac 12\operatorname {tr}((G^{1/2}AG^{1/2})^2)\le 0.\] The last matrix is real symmetric, and the trace of its square is the sum of the squares of its entries. Restricting to a line segment in the convex set \(\mathcal U_m\) proves concavity. This is also the Gram-square form of the Schur-product argument.
For completeness let \(X=d_e^T\phi \), \(Y=d_f^T\phi \), with variances \(\alpha ,\beta \) and covariance \(\gamma \). Their moment-generating function is \[\mathbb E[e^{sX+tY}] =\exp \left (\frac {\alpha s^2+2\gamma st+\beta t^2}{2}\right ).\] Differentiation at zero is justified by Gaussian exponential integrability, also when this pair is degenerate. The coefficient of \(s^2t^2\) is \(\alpha \beta /4+\gamma ^2/2\), hence \(\mathbb E[X^2Y^2]=\alpha \beta +2\gamma ^2\). Subtracting \(\mathbb E[X^2]\mathbb E[Y^2]\) proves the covariance identity.
[friedli2017statistical, Exercise 8.3, p. 385] states Wick's formula. The last calculation is its four-factor case and agrees with the Gaussian contraction rule. Concavity need not be strict in the weights: loops or dependent matrices \(d_ed_e^T\) can give zero second derivatives in nonzero directions.
Proposition. A massive sum rule and Foster's identity [fdip-005U]AGENTDRAFTED
- November 1, 2026
Proposition. A massive sum rule and Foster's identity [fdip-005U]AGENTDRAFTED
- November 1, 2026
For fixed nonnegative weights and \(m>0\), \[\sum _e w_e\frac {\partial \mathcal W}{\partial w_e} =\frac 12(n-m^2\operatorname {tr}G).\] If the positive-weight support is connected, its limit as \(m\downarrow 0\) is \((n-1)/2\). More explicitly, let \(L_w^+\) be zero on constant fields and the inverse of \(L_w\) on their orthogonal complement. The effective resistance between the endpoints of an edge is \(R_{\mathrm {eff}}(e)=d_e^TL_w^+d_e\), and \[\sum _e w_eR_{\mathrm {eff}}(e)=n-1.\] The resistance definition agrees with [spielman2009effective, p. 2].
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The edge derivative and cyclicity of trace give \[\sum _e w_e\frac {\partial \mathcal W}{\partial w_e} =\frac 12\operatorname {tr}(GL_w) =\frac 12\operatorname {tr}(I-m^2G).\] For connected positive support, the energy expression for \(L_w\) shows that its kernel consists exactly of constants. Choose an orthonormal eigenbasis \(u_0=n^{-1/2}\mathbf 1,u_1,\ldots ,u_{n-1}\), with positive nonconstant eigenvalues \(\lambda _j\). Then \[G=m^{-2}u_0u_0^T+ \sum _{j=1}^{n-1}(\lambda _j+m^2)^{-1}u_ju_j^T.\] Thus \(m^2\operatorname {tr}G\to 1\). Every incidence vector \(d_e\) is perpendicular to constants, so its quadratic form does not contain the divergent first term and tends to \(d_e^TL_w^+d_e\). Passing to the limit in the finite sum proves Foster's identity.
This is the projection-trace sum in [spielman2009effective, Lemma 3(iii), pp. 6-7; proof of Theorem 1, p. 8]. The massive law itself has no limit as a probability law on the full field space: its constant-mode variance diverges. Only the displayed edge observables have been passed to the limit. With \(k\) connected components the same eigenbasis argument replaces \(1\) by \(k\) in the trace limit.
Theorem. The determinant as a rooted-forest sum [fdip-005V]AGENTDRAFTED
- November 1, 2026
Theorem. The determinant as a rooted-forest sum [fdip-005V]AGENTDRAFTED
- November 1, 2026
A rooted spanning forest on \(V\) is an acyclic set \(F\subseteq E\) together with exactly one chosen vertex in each component, including isolated vertices. Write \(R\) for these roots and \(r=|R|\). Loops cannot occur, and distinct parallel labels count as distinct choices. With the data of Definition [fdip-005R], \[\det (L_w+m^2I) =\sum _{(F,R)}\left (\prod _{e\in F}w_e\right )m^{2|R|}.\] Normalize these nonnegative terms to obtain a probability law on rooted spanning forests. It satisfies \[\begin {aligned} \mathbb P(e\in F)&=w_ed_e^TGd_e,\\ \mathbb E[|R|]&=m^2\operatorname {tr}G,\\ \mathbb E[|F|]&=n-m^2\operatorname {tr}G. \end {aligned}\] If the positive-weight support is connected, with weighted spanning-tree sum \(\tau _w\), then \[\det (L_w+m^2I)=n\tau _wm^2+O(m^4) \qquad (m\downarrow 0).\] Thus the spanning-tree coefficient appears after division by \(m^2\); the unscaled determinant tends to zero.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Form the \(n\times (|E|+n)\) matrix with columns \(\sqrt {w_e}d_e\) for edges and \(m\delta _v\) for vertices. Call it \(A\); then \(AA^T=L_w+m^2I\). Cauchy-Binet expresses its determinant as the sum of the squared \(n\times n\) minors. A chosen minor consists of edge columns \(F\) and vertex columns \(R\), with \(|F|+|R|=n\). A cycle in \(F\) makes its incidence columns dependent (this includes a loop and the two-edge cycle of parallel edges), so only forests contribute.
Suppose \(F\) is a forest with components \(C_i\). Their incidence columns span the coordinate-sum-zero subspace in each \(\mathbb R^{C_i}\), of dimension \(|C_i|-1\). This follows by successively removing leaves. A component with no chosen vertex column therefore prevents full rank. There are as many chosen vertex columns as components, because \(|R|=n-|F|\); hence full rank requires exactly one in each component. Conversely, for a tree with one root, the matrix of its unweighted incidence columns and that root's coordinate vector has determinant \(\pm 1\): remove a nonroot leaf and expand along its row, then finish with the root's \(1\times 1\) matrix. Applying this to all components proves that precisely the stated forests contribute, with squared minor \((\prod _{e\in F}w_e)m^{2|R|}\). Zero-weight edge columns vanish, consistent with deletion.
Put \(t=m^2\) and call this polynomial \(D(w,t)\). Termwise differentiation gives \(w_e\partial _eD=\sum _{F\ni e,R}(\prod _{f\in F}w_f)t^{|R|}\) and \(t\partial _tD=\sum _{F,R}|R|(\prod _{f\in F}w_f)t^{|R|}\). Divide by \(D>0\) and use the determinant derivative from Theorem [fdip-005S], first in direction \(d_ed_e^T\), then in direction \(I\). The edge identity holds also at \(w_e=0\), when both sides vanish. Finally every forest has \(|F|+|R|=n\). For connected positive support, the coefficient of \(t\) comes from spanning trees; each has \(n\) choices of root. All other terms have at least two roots and hence order \(t^2\).
Equivalently, add a new boundary vertex \(*\) with an edge of weight \(m^2\) to each old vertex. Attach \(*\) to the chosen root of each forest component; this is a bijection to spanning trees of the augmented graph. Its Dirichlet Laplacian at \(*\) is \(L_w+m^2I\). This is the trivial-connection case of Kenyon's boundary theorem: cycle factors vanish, leaving trees rooted at the boundary [kenyon2011spanning, Theorem 7, Section 8, p. 15]. The conductance extension is given in [kenyon2011spanning, Section 7.1, Theorem 5, p. 13]. The proof above includes the needed weights and zero-weight faces. Chaiken's all-minors matrix-tree theorem enumerates directed forests by the minors of a Laplacian whose columns sum to zero [chaiken1982minors, pp. 319-329]. The expansion proved above is the undirected weighted case, obtained from Cauchy-Binet. It does not reproduce Chaiken's directed sign rule.
TauCeti's
Matrix.det_mul_transpose_eq_sum_plucker_sq
gives the Cauchy-Binet identity for a matrix over a commutative
ring with rows indexed by \(\mathrm {Fin}(n)\) and a finite ordered
column set. Reindexing the present real matrix supplies those
hypotheses. Its Plücker coordinates are the maximal minors.
This supports the sum-of-squares step; the classification of
nonzero forest minors and the probability consequences are
proved here.
Example. Edge derivatives and forests on an alternating cycle [fdip-005W]AGENTDRAFTED
- November 1, 2026
Example. Edge derivatives and forests on an alternating cycle [fdip-005W]AGENTDRAFTED
- November 1, 2026
Take the four-cycle \(0\to 1\to 2\to 3\to 0\) with weights \((1,2,1,2)\) and \(m=1\). The orthonormal vectors \[\begin {aligned} u_0&=\tfrac 12(1,1,1,1),&u_2&=\tfrac 12(1,-1,-1,1),\\ u_4&=\tfrac 12(1,1,-1,-1),&u_6&=\tfrac 12(1,-1,1,-1) \end {aligned}\] have \(L_w\)-eigenvalues given by their subscripts, as direct multiplication verifies. Therefore \(Q\) has eigenvalues \(1,3,5,7\), and \[\det Q=105,\qquad \operatorname {tr}G =1+\frac 13+\frac 15+\frac 17=\frac {176}{105}.\] The edge vector \(d_{01}\) has squared projection \(1\) onto each of \(u_2,u_6\), and zero onto the other two. For \(d_{12}\) the nonzero squared projections are onto \(u_4,u_6\). Half-turn symmetry gives the other two edges. Thus \[\frac {\partial \mathcal W}{\partial w_e} =\begin {cases} \frac 12(\frac 13+\frac 17)=\frac 5{21}&w_e=1,\\ \frac 12(\frac 15+\frac 17)=\frac 6{35}&w_e=2. \end {cases}\] These are individual edge derivatives at the displayed weights; they are not derivatives of a simultaneous change of both edges of one weight. The weighted sum is \[2\cdot \frac 5{21}+4\cdot \frac 6{35} =\frac {122}{105} =\frac 12\left (4-\frac {176}{105}\right ).\] This is an instance of Proposition [fdip-005U].
The forest generating polynomial is \[\begin {aligned} \det (tI+L_w)&=t(t+2)(t+4)(t+6)\\ &=t^4+12t^3+44t^2+48t. \end {aligned}\] The 4 spanning trees have weights \(4,2,4,2\), so \(\tau _w=12\) and the coefficient of \(t\) is \(4\tau _w=48\). At \(t=1\), the forest law has \[\mathbb E[|R|]=\frac {176}{105},\qquad \mathbb E[|F|]=\frac {244}{105}.\] Its individual edge probabilities are \(10/21\) on weight-one edges and \(24/35\) on weight-two edges. They sum to \(244/105\), as the forest identity requires.
On the unit four-cycle, all 4 edges instead have the same effective resistance by rotation. One unit edge is in parallel with the other three in series, giving \(R_{\mathrm {eff}}=3/4\). Equivalently the nonconstant spectral calculation gives \(1/2+1/4=3/4\). Foster's sum is \(4(3/4)=3\), matching \(n-1\). This is an edge-observable limit, not a massless Gaussian law on all 4 vertex values.
Example. A finite cycle determinant and its circle scaling [fdip-005X]AGENTDRAFTED
- November 1, 2026
Example. A finite cycle determinant and its circle scaling [fdip-005X]AGENTDRAFTED
- November 1, 2026
For the unit-weight cycle \(C_n\), \(n\ge 3\), let \(c>0\) and define \(\omega >0\) by \(2\cosh \omega =2+c\). Then \[\det (cI+L_{C_n})=2\cosh (n\omega )-2 =4\sinh ^2(n\omega /2).\] This uses the nearest-neighbor Laplacian \(L_{C_n}=2I-T_n-T_n^{-1}\), with every undirected edge counted once. The condition \(n\ge 3\) avoids replacing the two-vertex cycle by a different parallel-edge convention.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Complex Fourier vectors diagonalize \(T_n\); write \(\zeta _k=e^{2\pi ik/n}\) and \(z=e^\omega >1\). The eigenvalues of \(cI+L_{C_n}\) are \[c+2-\zeta _k-\zeta _k^{-1} =z^{-1}(z-\zeta _k)(z-\zeta _k^{-1}).\] Since inversion permutes the \(n\)-th roots of unity, their product is \[z^{-n}(z^n-1)^2=z^n+z^{-n}-2.\] This equals the real determinant: complexification does not change the determinant of the original real matrix.
Now fix \(\mu >0\), set \(c=\mu /n^2\), and write \(\omega _n\) for the corresponding solution. Since \(2\cosh x-2=x^2+O(x^4)\) at zero, \(\omega _n\to 0\) and \(n\omega _n\to \sqrt \mu \). Therefore \[\det (\mu n^{-2}I+L_{C_n}) \longrightarrow 4\sinh ^2(\sqrt {\mu }/2).\] For the circle mesh, with \(L_n=n^2L_{C_n}\) and \(Q_n=L_n+\mu I\), this is exactly \[\frac {\det Q_n}{n^{2n}} \longrightarrow 4\sinh ^2(\sqrt {\mu }/2),\] or, in the induced-action notation, \[\frac 12\log \det Q_n-n\log n \longrightarrow \log \left (2\sinh (\sqrt {\mu }/2)\right ).\] The determinant here is that of the operator \(Q_n\), equivalently its matrix in an orthonormal basis for the supplied normalized pairing. In raw vertex coordinates the action-form matrix is \(Q_n/n\); its determinant carries the additional factor \(n^{-n}\). Thus a reference measure convention still matters when passing from this operator calculation to a Gaussian integral.
This finite-product limit complements the fixed-mode covariance limit and the exact cycle covariance. It does not define an infinite product without a normalization, prove convergence of full-field measures, or identify the limit with a continuum determinant under an unstated regularization convention. The positive mass is fixed throughout.
Definition. An interaction on a selected background [fdip-005Y]AGENTDRAFTED
- November 1, 2026
Definition. An interaction on a selected background [fdip-005Y]AGENTDRAFTED
- November 1, 2026
An interacting selected background consists of a selected Gaussian background \(b=(\Pi ,w,m,P)\), a real polynomial \(\mathcal V:H\to \mathbb R\), and a formal variable \(\lambda \). Thus the precision \(Q>0\), metric and selector are supplied along with the interaction. Write \(X=\operatorname {im}P\) and \(Y=\ker P\), so \(H=X\mathbin \perp Y\).
For every \(x\in X\), define a probability law on \(Y\) by \[\begin {aligned} Z_b(x)&=\int _Y e^{-\frac 12\langle x+y,Q(x+y)\rangle }\,dy,\\ \kappa _{b,x}(dy) &=Z_b(x)^{-1}e^{-\frac 12\langle x+y,Q(x+y)\rangle }\,dy. \end {aligned}\] The volume \(dy\) is the induced Euclidean volume. Positive precision makes \(Z_b(x)\) positive and finite. The square-completion formula shows that this is a Gaussian law whose mean depends linearly on \(x\). It is the conditional law of the eliminated field given the retained value, using the canonical density formula at every \(x\); general regular conditional laws are unique only almost everywhere.
The fiber effective interaction is the formal series \[\begin {aligned} M_{b,\mathcal V}(\lambda ,x) &=\sum _{n\ge 0}\frac {(-\lambda )^n}{n!} \int _Y\mathcal V(x+y)^n\,\kappa _{b,x}(dy),\\ F_{b,\mathcal V}(\lambda ,x)&=-\log M_{b,\mathcal V}(\lambda ,x). \end {aligned}\] Each coefficient is a polynomial on \(X\): expand the polynomial about the conditional mean and use the fixed centered Gaussian moments. These moments are finite by polynomial integrability. The series \(M\) has constant coefficient one, so its logarithm is a formal power series in \(\lambda \) with coefficients in the real polynomial algebra \(\mathcal P(X)\) on \(X\). This extends the quartic construction to any polynomial interaction and any orthogonal selector. Constants in \(x\) remain part of \(F\).
This definition is coefficientwise. It imposes no positivity on \(\mathcal V\), asserts no convergence for nonzero \(\lambda \), and uses no interchange of an infinite sum with an integral. The notation \(O(\lambda ^k)\) means divisibility by \(\lambda ^k\). A fiber logarithm is different from the Legendre transform that defines a one-particle irreducible effective action in [etingof2024mathematical, v2, Proposition 3.23, p. 50]. Here the retained field is fixed while its orthogonal complement is integrated.
Theorem. Naturality of the fiber interaction [fdip-005Z]AGENTDRAFTED
- November 1, 2026
Theorem. Naturality of the fiber interaction [fdip-005Z]AGENTDRAFTED
- November 1, 2026
Let \(b,b'\) be selected backgrounds with polynomial interactions \(\mathcal V,\mathcal V'\). Suppose a background arrow has vertex counting isometry \(U:H\to H'\) and satisfies \(\mathcal V'\circ U=\mathcal V\). Then the fiber interactions obey, to all formal orders, \[F_{b',\mathcal V'}(\lambda ,Ux) =F_{b,\mathcal V}(\lambda ,x)\qquad (x\in X).\] The assertion also holds for signed endpoint arrows. More generally, it holds for an orthogonal isomorphism \(O:H\to H'\) satisfying \[Q'=OQO^{-1},\qquad P'=OPO^{-1},\qquad \mathcal V'\circ O=\mathcal V,\] with \(Ox\) in place of \(Ux\). This latter statement uses the wider orthogonal comparison, which need not preserve incidence.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
It suffices to prove the orthogonal statement. The equation for \(P'\) gives isometries \(O_X:X\to X'\) and \(O_Y:Y\to Y'\). For \(x\in X\) and \(y\in Y\), \[\langle O_Xx+O_Yy,Q'(O_Xx+O_Yy)\rangle =\langle x+y,Q(x+y)\rangle .\] The change of variables \(y'=O_Yy\) has absolute Jacobian one for the induced Euclidean volumes. Consequently \(Z_{b'}(O_Xx)=Z_b(x)\) and \[(O_Y)_*\kappa _{b,x}=\kappa _{b',O_Xx}.\] Transport of \(\mathcal V\) now gives, for every integer \(n\ge 0\), \[\begin {aligned} &\int _{Y'}\mathcal V'(O_Xx+y')^n\,\kappa _{b',O_Xx}(dy')\\ &\qquad =\int _Y\mathcal V(x+y)^n\,\kappa _{b,x}(dy). \end {aligned}\] The integrals are finite. Thus the two moment series agree after pullback, and so do their formal logarithms. A directed or signed background arrow supplies the required conjugacy of \(Q,P\), proving the graph cases as well.
Each coefficient of \(F\) is therefore a polynomial transported by the same retained isometry. Its homogeneous parts correspond by polarization to symmetric tensors on \(X\). A background automorphism that also preserves \(\mathcal V\) fixes these polynomials and tensors; choosing coordinates only records their components. Arbitrary components need not be unchanged by an orthogonal change of basis. Likewise a graph symmetry need not preserve a supplied interaction. The invariance assertion uses both the background and interaction transport equations.
Proposition. Conditional propagators and induced vertices [fdip-0060]AGENTDRAFTED
- November 1, 2026
Proposition. Conditional propagators and induced vertices [fdip-0060]AGENTDRAFTED
- November 1, 2026
For an interacting selected background, put \(n=\dim H\) and \(r=\operatorname {rank}P\), and choose orthonormal basis maps \(B:\mathbb R^r\to X\) and \(B_\perp :\mathbb R^{n-r}\to Y\). Thus a full field is \(\phi =Bx+B_\perp y\); in this proposition \(x,y\) denote coordinates. Set \[\begin {aligned} A&=B^TQB,&K&=B^TQB_\perp ,\\ D&=B_\perp ^TQB_\perp >0,&S&=A-KD^{-1}K^T. \end {aligned}\] The eliminated coordinates, conditionally on \(x\), have law \[y=\mu (x)+\eta ,\qquad \mu (x)=-D^{-1}K^Tx,\qquad \eta \sim N(0,D^{-1}).\] In particular the full conditional mean and noise covariance are \[h(x)=Bx+B_\perp \mu (x),\qquad C=B_\perp D^{-1}B_\perp ^T.\] The map \(h\) is the harmonic extension: \(B^Th(x)=x\) and \(B_\perp ^TQh(x)=0\). It is the unique minimizer of the quadratic energy among fields with these retained coordinates.
Write \(F_\lambda (x)=F_{b,\mathcal V}(\lambda ,Bx)\). Then \[\begin {aligned} a(x)&=\mathbb E\mathcal V(h(x)+B_\perp \eta ),\\ b(x)&=\operatorname {Var}\bigl (\mathcal V(h(x)+B_\perp \eta )\bigr ),\\ F_\lambda (x)&=\lambda a(x)-\frac {\lambda ^2}{2}b(x) +O(\lambda ^3). \end {aligned}\] Thus external mean factors in the conditional moment expansion use \(h(x)\), and each internal pairing of eliminated coordinates uses \(D^{-1}\). These are the background-dependent Feynman rules for this fiber integral. In full-field components the internal pairing is \(C\); the eliminated mean \(\mu \) alone omits the retained part of \(h\). For a coordinate selector retaining \(R\) and eliminating \(U=V\setminus R\), the formulas become \[\mu (x)=-Q_{UU}^{-1}Q_{UR}x,\qquad \operatorname {Cov}(\eta )=Q_{UU}^{-1}.\]
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Orthogonality preserves the volume and gives \[\begin {aligned} \langle \phi ,Q\phi \rangle &=x^TAx+2x^TKy+y^TDy\\ &=x^TSx+(y+D^{-1}K^Tx)^TD(y+D^{-1}K^Tx). \end {aligned}\] The second term is minimized uniquely at \(y=\mu (x)\). Normalizing its density proves the conditional law at every \(x\). Writing \(v_x(y)=Bx+B_\perp y\), it also gives \[\begin {aligned} c_D&=\frac {(2\pi )^{(n-r)/2}}{\sqrt {\det D}},\\ \int _{\mathbb R^{n-r}}&e^{-\frac 12\langle v_x(y),Qv_x(y)\rangle } e^{-\lambda \mathcal V(v_x(y))}\,dy\\ &=c_De^{-\frac 12x^TSx}e^{-F_\lambda (x)}. \end {aligned}\] The last equality means equality after integrating each polynomial coefficient. Hence it retains the scalar and degree-zero terms as well as the induced polynomial vertices.
The moment series starts with \(1-\lambda a+\lambda ^2\mathbb E[\mathcal V^2\mid x]/2+O(\lambda ^3)\). Applying \(-\log (1+z)=-z+z^2/2+O(z^3)\) gives the displayed variance coefficient. In each moment, expand around \(h(x)\). Odd centered Gaussian moments vanish; every even moment is a sum over pairings, with one \(D^{-1}\) entry per pair in eliminated coordinates. This is [etingof2024mathematical, v2, Theorem 3.1 and Example 3.2, p. 29] applied to the positive form \(D\). For a quartic \(\mathcal V(\phi )=T(\phi ,\phi ,\phi ,\phi )/24\), the first coefficient has degrees \(4,2,0\). In the variance, pairings with no contraction between the two copies cancel, leaving degrees among \(6,4,2,0\), as shown in Proposition [fdip-0046]. All these claims concern finite polynomial coefficients.
For example, in full vertex coordinates with the symmetric four-tensor \(T_{ijkl}\) and \(h=h(x)\), Wick's three pairings give \[\begin {aligned} 24a(x)={}&T(h,h,h,h) +6\sum _{i,j,k,l}T_{ijkl}h_i h_j C_{kl}\\ &+3\sum _{i,j,k,l}T_{ijkl}C_{ij}C_{kl}. \end {aligned}\] The covariance \(C\) can be singular on \(H\): it is supported on \(Y\), and the formula follows by applying Wick to the nonsingular \(D^{-1}\) in eliminated coordinates. No nondegeneracy on all of \(H\) is needed for this expression.
TauCeti's
integral_mul_mul_mul_multivariateGaussian
proves the three-pairing identity for 4 centered Gaussian
coordinates, allowing repeated indices and any positive-semidefinite
covariance. Setting that covariance to \(C\) supplies the fourth-moment
step here. Contraction with \(T\), the formal logarithm and the
higher-moment pairing arguments are the additional deductions above.
The massive lattice analogue is [friedli2017statistical, Theorem 8.26, p. 399]: on a finite domain of \(\mathbb Z^d\), the conditional field has the massive harmonic mean determined by its boundary values and a killed-walk Green covariance. That theorem uses its normalized lattice Laplacian; it does not supply the arbitrary-projector argument above. The massless finite-domain analogue is Theorem 8.17, p. 391 of the same source.
A formal conditional-distribution counterpart in TauCeti is
condDistrib_multivariateGaussian.
It assumes a positive-semidefinite joint covariance and a
positive-definite observed covariance block, and identifies the
regular conditional law with an explicit Gaussian kernel almost
everywhere in the observed marginal. To specialize, order the
coordinates as \(Y\oplus X\) and use \(G=Q^{-1}>0\). From \(QG=I\),
\[\begin {aligned}
DG_{YX}+K^TG_{XX}&=0,\\
DG_{YY}+K^TG_{XY}&=I.
\end {aligned}\]
Therefore \(G_{YX}G_{XX}^{-1}=-D^{-1}K^T\) and
\(G_{YY}-G_{YX}G_{XX}^{-1}G_{XY}=D^{-1}\), the theorem's mean
and covariance formulas. Its almost-everywhere identification is
distinct from the explicit density kernel used here at every \(x\).
The perturbative logarithm and vertex calculations are proved above.
Example. Quartic vertices on an alternating cycle [fdip-0061]AGENTDRAFTED
- November 1, 2026
Example. Quartic vertices on an alternating cycle [fdip-0061]AGENTDRAFTED
- November 1, 2026
On the alternating four-cycle with weights \((1,t,1,t)\), take \(t>0\), \(m>0\) and \(s=1+t+m^2\). Retain \(R=\{0,2\}\), eliminate \(U=\{1,3\}\), and choose the interaction \[\mathcal V(\phi )=\frac {\phi _1^4+\phi _3^4}{24}.\] In retained coordinates \(x=(x_0,x_2)\), the conditional rules give independent eliminated noises of variance \(1/s\), with means \[\mu _1=\frac {x_0+tx_2}{s},\qquad \mu _3=\frac {tx_0+x_2}{s}.\] The first coefficient \(a(x)\) of the fiber interaction is \[\begin {aligned} a(x)={}&\frac {(1+t^4)(x_0^4+x_2^4)}{24s^4}\\ &+\frac {4t(1+t^2)(x_0^3x_2+x_0x_2^3) +12t^2x_0^2x_2^2}{24s^4}\\ &+\frac {(1+t^2)(x_0^2+x_2^2)+4tx_0x_2}{4s^3} +\frac 1{4s^2}. \end {aligned}\] Thus eliminating a quartic supported on the removed vertices creates quartic and quadratic couplings on the retained vertices, as well as a constant.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The eliminated precision is \(D=sI_2\); its cross block gives the two means above. For a centered real Gaussian \(\eta \) of variance \(v\), Wick's identity gives \(\mathbb E\eta ^4=3v^2\). Expanding \((\mu +\eta )^4\) and discarding odd moments yields \[\mathbb E(\mu +\eta )^4=\mu ^4+6\mu ^2v+3v^2.\] Consequently \[a(x)=\frac {\mu _1^4+\mu _3^4}{24} +\frac {\mu _1^2+\mu _3^2}{4s}+\frac 1{4s^2}.\] The binomial expansions of \((x_0+tx_2)^4+(tx_0+x_2)^4\) give coefficients \(1+t^4\), \(4t(1+t^2)\) and \(12t^2\). Squaring the two numerators gives \((1+t^2)(x_0^2+x_2^2)+4tx_0x_2\). Substitution proves every coefficient in the displayed polynomial.
In these named vertex coordinates, the ratio of the \(x_0^3x_2\) coefficient to the \(x_0^4\) coefficient is \[r(t)=\frac {4t(1+t^2)}{1+t^4}.\] It is unchanged by exchanging the two retained vertices and obeys \[\begin {aligned} r(t)&=r(1/t),&r(2)=r(1/2)&=\frac {40}{17},\\ r'(t)&=\frac {4(1-t^2)(1+4t^2+t^4)}{(1+t^4)^2}. \end {aligned}\] The derivative is positive for \(0<t<1\). Therefore \(r\) separates the parameter for \(0<t\le 1\), and on all positive parameters it separates exactly modulo \(t\leftrightarrow1/t\). This is a vertex-coordinate shape ratio, not an invariant of arbitrary orthogonal changes of the retained basis. The complete coefficient tensors instead obey the naturality theorem.
The reciprocal equality resembles that of the trace ratio, but neither equality gives a strict fixed-mass background isomorphism at reciprocal parameters. The edge-weight products are \(t^2\) and \(t^{-2}\), so a weight-preserving edge bijection would force \(t=1\). Also \(s\) changes at fixed mass; equality of the shape ratio does not make all induced coefficients equal.
A finite illustration uses \(t=2\), \(m=1\) and \(x=(0.5,-0.3)\). The means are \((-1/40,7/40)\), and the exact coefficient is \[a(x)=\frac {541201}{30720000}.\] The polynomial identity is the calculation above. The same conditional moment is the one exercised by the project script revision-checks.py.
Remark. How the selector changes induced interactions [fdip-0062]AGENTDRAFTED
- November 1, 2026
Remark. How the selector changes induced interactions [fdip-0062]AGENTDRAFTED
- November 1, 2026
A comparison of selectors should hold the full interaction fixed. On the alternating cycle of Example [fdip-0061], now use \[\mathcal V_{\mathrm {tot}}(\phi )=\frac 1{24}\sum _{v=0}^3\phi _v^4.\] For opposite retained vertices \(R=\{0,2\}\), add \((x_0^4+x_2^4)/24\) to that example's first coefficient. The eliminated covariance is \(s^{-1}I_2\). For adjacent retained vertices \(R=\{0,1\}\), the eliminated coordinates are \((\phi _2,\phi _3)\), and \[\begin {aligned} D&=\begin {pmatrix}s&-1\\-1&s\end {pmatrix},\\ D^{-1}&=\frac 1{s^2-1}\begin {pmatrix}s&1\\1&s\end {pmatrix},\\ \mu (x)&=\frac {t}{s^2-1} \begin {pmatrix}1&s\\s&1\end {pmatrix} \begin {pmatrix}x_0\\x_1\end {pmatrix}. \end {aligned}\] Here \(s>1\), so the denominator is positive. These formulas follow from \(Q_{UR}=\left (\begin {smallmatrix}0&-t\\-t&0\end {smallmatrix}\right )\) and the conditional rules.
The adjacent first coefficient is explicitly \[\begin {aligned} a_{\mathrm {adj}}(x)={}&\frac {x_0^4+x_1^4}{24}\\ &+\frac 1{24}\sum _{j=2,3} \bigl (\mu _j(x)^4+6\mu _j(x)^2v+3v^2\bigr ),\\ v={}&\frac {s}{s^2-1}. \end {aligned}\] In particular its constant term is \(s^2/[4(s^2-1)^2]\), whereas the opposite selector gives \(1/(4s^2)\). They are unequal for \(s>1\). The adjacent propagator also has a nonzero cross entry \(1/(s^2-1)\) between eliminated vertices, which contributes pairings between their quartics in the variance coefficient. Such a cross entry is absent for opposite elimination. Thus the same precision and full interaction yield different conditional contraction rules and induced vertices when the selector changes.
For a restricting selector, \(PQ=QP\) makes the cross block \(K\) zero. The Gaussian law then factors between \(X\) and \(Y\), and the eliminated conditional mean is zero. Any remaining coupling between the two subspaces comes from \(\mathcal V\), not from a Gaussian cross term. In particular, if \(\mathcal V(x+y)=\mathcal V_X(x)+\mathcal V_Y(y)\), then \[F_\lambda (x)=\lambda \mathcal V_X(x) -\log \mathbb E_{N(0,D^{-1})}e^{-\lambda \mathcal V_Y}.\] The second term is a formal scalar independent of \(x\). If the interaction has mixed terms, new retained vertices can still be induced even though the Gaussian selector restricts. Group-algebra selectors restrict under the stated equivariance hypothesis; a subrepresentation selector need not.
These formulas answer the finite perturbative question: the propagator and induced interaction depend on the supplied background and selector. They do not establish convergence of the formal series, a continuum interacting measure, or a physical mechanism that selects the background.
Local Gaussian laws and gluing [fdip-0063]AGENTDRAFTED
- November 1, 2026
Local Gaussian laws and gluing [fdip-0063]AGENTDRAFTED
- November 1, 2026
Eliminating fields gives a law on a subset of vertices. This chapter asks the reverse question: when do prescribed laws on overlapping subsets come from one global law? Agreement on overlaps is necessary, but it can leave many extensions or permit none. The distinction is already visible on two vertices and on a four-cycle.
Zeros in a positive precision matrix express conditional independence. They give an exact density formula for joining two laws across a separator. For a chordal graph, its maximal cliques can be arranged in a junction tree, so the formula can be iterated. The resulting law is unique with the stated Markov condition. This finite gluing result is distinct from scalar factorization and from a stack of background objects.
Definition. Local Gaussian data and marginal restriction [fdip-0064]AGENTDRAFTED
- November 1, 2026
Definition. Local Gaussian data and marginal restriction [fdip-0064]AGENTDRAFTED
- November 1, 2026
Fix a finite vertex set \(V\). For every subset \(T\subseteq V\), let \(\mathcal G(T)\) be the set of centered real Gaussian probability laws on \(\mathbb R^T\) with positive-definite covariance. Put \(\mathcal G(\varnothing )=\{1\}\), the unit mass on the zero-dimensional space. For \(S\subseteq T\), coordinate projection \(\pi _{S,T}:\mathbb R^T\to \mathbb R^S\) defines marginal restriction \[\operatorname {res}_{S,T}\mu =(\pi _{S,T})_*\mu .\] If \(\mu =N(0,G)\), its restriction is \(N(0,G_{SS})\); a principal submatrix of \(G>0\) is positive definite. Identity and composition of projections make \(\mathcal G\) a presheaf on the poset of all subsets of \(V\).
A cover of \(T\) is a finite family \((T_i)\) with \(\bigcup _iT_i=T\). A family \(\mu _i\in \mathcal G(T_i)\) is compatible local Gaussian data if its two marginals on each \(T_i\cap T_j\) agree. A global extension is a law \(\mu \in \mathcal G(T)\) with these restrictions. In covariance coordinates, compatibility means equality of the two principal submatrices on each overlap.
The domain contains all subsets and all such positive Gaussian laws. It is not restricted to the Markov laws of one fixed graph: marginalizing vertices can create new precision entries. For a law with precision \(Q=G^{-1}\), the Schur formula gives the precision of its \(S\)-marginal as \[\Lambda _S=(G_{SS})^{-1} =Q_{SS}-Q_{S,S^c}Q_{S^c,S^c}^{-1}Q_{S^c,S},\] where \(S^c=T\setminus S\). This is generally different from \(Q_{SS}\). Empty blocks follow the zero-dimensional convention.
The two-singleton example shows why overlap compatibility alone does not ensure uniqueness.
Example. One-vertex marginals with many extensions [fdip-006A]AGENTDRAFTED
- November 1, 2026
Example. One-vertex marginals with many extensions [fdip-006A]AGENTDRAFTED
- November 1, 2026
Compatibility of local Gaussian data alone does not imply uniqueness. On the cover \(\{0\},\{1\}\) of two vertices, prescribe a standard normal law at each vertex. Every covariance \[G_\rho =\begin {pmatrix}1&\rho \\\rho &1\end {pmatrix}, \qquad -1<\rho <1,\] is a positive-definite global extension. The product law is the member \(\rho =0\). Uniqueness will require an additional conditional-independence condition.
Theorem. Precision zeros and Gaussian conditional independence [fdip-0065]AGENTDRAFTED
- November 1, 2026
Theorem. Precision zeros and Gaussian conditional independence [fdip-0065]AGENTDRAFTED
- November 1, 2026
Let \(\phi \sim N(0,Q^{-1})\) on \(\mathbb R^V\), where \(Q\) is any real symmetric positive-definite matrix. Its precision graph has an edge \(\{a,b\}\) for distinct vertices exactly when \(Q_{ab}\ne 0\). For pairwise disjoint subsets \(A,B,S\), say that \(S\) separates \(A\) from \(B\) if every graph path from \(A\) to \(B\) meets \(S\). Then \[S\text { separates }A\text { from }B \quad \Longrightarrow \quad \phi _A\mathrel {\perp \mkern -9mu\perp }\phi _B\mid \phi _S.\] Here conditional independence means that the conditional joint law factors into its two conditional marginals almost everywhere in \(\phi _S\). The canonical Gaussian density kernels used below factor at every conditioning value. For distinct vertices there is also the pairwise equivalence \[Q_{ab}=0\quad \Longleftrightarrow \quad \phi _a\mathrel {\perp \mkern -9mu\perp }\phi _b \mid \phi _{V\setminus \{a,b\}}.\] No Laplacian sign condition on \(Q\) is required.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
First suppose \(V=A\sqcup S\sqcup B\). Separation implies \(Q_{AB}=0\). With \(\phi _S=s\) fixed, the quadratic energy in \(a,b\) is the sum \[\begin {aligned} &\frac 12a^TQ_{AA}a+a^TQ_{AS}s\\ &\qquad +\frac 12b^TQ_{BB}b+b^TQ_{BS}s +\frac 12s^TQ_{SS}s. \end {aligned}\] The last term is constant. The two remaining positive Gaussian factors normalize separately, proving independence at every \(s\). Equivalently, the conditional precision is \(\operatorname {diag}(Q_{AA},Q_{BB})\); its inverse has zero cross block. The square completion is the coordinate case of Proposition [fdip-0060].
For smaller disjoint \(A,B,S\), no connected component of the graph on \(V\setminus S\) meets both \(A\) and \(B\). Assign its components to two unions \(A',B'\) with \(A\subseteq A'\), \(B\subseteq B'\) and \(A'\sqcup B'=V\setminus S\); components meeting neither may be assigned arbitrarily. The preceding argument gives conditional independence of \(\phi _{A'}\) and \(\phi _{B'}\) given \(s\). Taking coordinate marginals gives the asserted independence of \(\phi _A\) and \(\phi _B\).
For the pairwise statement, fixing all other coordinates leaves conditional precision and cross covariance \[\begin {pmatrix}Q_{aa}&Q_{ab}\\Q_{ab}&Q_{bb}\end {pmatrix}, \qquad \operatorname {Cov}(\phi _a,\phi _b\mid \phi _{V\setminus \{a,b\}}) =\frac {-Q_{ab}}{Q_{aa}Q_{bb}-Q_{ab}^2}.\] The denominator is positive. Independence implies zero covariance, and zero \(Q_{ab}\) makes the conditional density a product. This proves both directions.
A positive Gaussian law is Markov with respect to a graph \(\Gamma \) if its precision is zero on all distinct nonedges of \(\Gamma \); extra zeros on edges are allowed. The same proof gives conditional independence across every separator of \(\Gamma \). Conversely its separator condition implies these zeros by taking \(S=V\setminus \{a,b\}\) for each nonedge. This is the finite Gaussian global Markov equivalence of [speed1986gaussian, Proposition 1 and Corollary 1, p. 139; Proposition 2, pp. 140–141]. The lattice harmonic-field statements of [friedli2017statistical, Theorems 8.17 and 8.26, pp. 391 and 399] concern their specified lattice precisions, not this arbitrary-precision theorem.
Mathlib's
ProbabilityTheory.HasGaussianLaw.indepFun_of_covariance_eval
supports the independence step for two finite coordinate families
with a jointly Gaussian law and zero cross covariances. Apply it
separately to the conditional Gaussian at each fixed \(s\); the block
inverse above verifies its covariance hypothesis. The declaration
asserts ordinary independence under that probability law. Graph
separation, the passage to conditional kernels and the pairwise
converse are supplied by the argument above.
Theorem. Gluing two Gaussian laws across a separator [fdip-0066]AGENTDRAFTED
- November 1, 2026
Theorem. Gluing two Gaussian laws across a separator [fdip-0066]AGENTDRAFTED
- November 1, 2026
Let \(V=V_1\cup V_2\), \(S=V_1\cap V_2\), \(A=V_1\setminus S\) and \(B=V_2\setminus S\). Suppose positive-definite centered Gaussian laws \(\mu _1,\mu _2\) have the same marginal \(\mu _S\). Write \(p_1,p_2,p_S\) for their positive Lebesgue densities. There is exactly one positive Gaussian extension with \(\phi _A\mathrel {\perp \mkern -9mu\perp }\phi _B\mid \phi _S\). Its density is \[p(a,s,b)=\frac {p_1(a,s)p_2(s,b)}{p_S(s)}.\] If \(S=\varnothing \), take \(p_S=1\); this is the product law.
Let \(\Lambda _1,\Lambda _2,\Lambda _S\) denote the three marginal precision matrices. Padding a matrix on \(T\) with zeros gives the matrix on \(V\) defined by \[\operatorname {pad}_T(M)=\pi _T^TM\pi _T.\] The extension's precision is \[Q=\operatorname {pad}_{V_1}(\Lambda _1) +\operatorname {pad}_{V_2}(\Lambda _2) -\operatorname {pad}_S(\Lambda _S).\] In particular, if a positive global Gaussian law has \(S\) separating \(A\) and \(B\) in its precision graph, this formula reconstructs its precision from the indicated marginals. The matrices \(\Lambda _i\) are marginal precisions, not principal restrictions of \(Q\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Factor the proposed density as \(p_S(s)p_1(a\mid s)p_2(b\mid s)\). Successively integrating over \(a,b,s\) gives total mass one. Integrating just \(b\) or just \(a\) recovers \(p_1\) or \(p_2\), respectively; its conditional density is visibly a product. Completing the two local squares writes the quadratic form in its exponent \(-q/2\) as \[\begin {aligned} q(a,s,b)={}&s^T\Lambda _Ss +(a-M_1s)^TD_1(a-M_1s)\\ &+(b-M_2s)^TD_2(b-M_2s), \end {aligned}\] where \(D_1,D_2>0\) are the conditional precisions and \(M_1,M_2\) are the conditional mean maps. This form is positive definite: if it is zero, its three nonnegative terms force first \(s=0\), then \(a=b=0\). The density is therefore a centered positive Gaussian. Subtracting the three density exponents gives the displayed padding formula. These statements include empty coordinate spaces.
For any extension with the asserted conditional independence, its conditional marginals must equal the two prescribed conditional marginals almost everywhere. Its density is consequently the same product almost everywhere, proving uniqueness as a probability law. For an existing global law the Markov theorem supplies this independence. This is the density factorization underlying [speed1986gaussian, Propositions 1–2, pp. 139–141]; the construction here also proves positive-definite existence from the two compatible input laws.
The four-cycle calculation displays the marginal precisions and reconstructs every entry by this formula.
Example. Separator reconstruction on the four-cycle [fdip-006B]AGENTDRAFTED
- November 1, 2026
Example. Separator reconstruction on the four-cycle [fdip-006B]AGENTDRAFTED
- November 1, 2026
Apply separator gluing to the unit four-cycle with mass \(m=1\).
The doubled vertices form the separator \(S=\{0,2\}\). The cover sets are \(V_1=\{0,1,2\}\) and \(V_2=\{0,2,3\}\); their private vertices \(1,3\) have no connecting edge. The graph has only the 4 drawn edges, with no diagonal edge. Its precision is \[Q=\begin {pmatrix} 3&-1&0&-1\\-1&3&-1&0\\0&-1&3&-1\\-1&0&-1&3 \end {pmatrix}.\] Use \(V_1=(0,1,2)\), \(V_2=(0,2,3)\) and \(S=(0,2)\), with the listed coordinate orders. Each omitted vertex has precision \(3\), so the Schur formula gives \[\begin {aligned} \Lambda _1&=\begin {pmatrix} 8/3&-1&-1/3\\-1&3&-1\\-1/3&-1&8/3 \end {pmatrix},\\ \Lambda _2&=\begin {pmatrix} 8/3&-1/3&-1\\-1/3&8/3&-1\\-1&-1&3 \end {pmatrix},\\ \Lambda _S&=\begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix}. \end {aligned}\] Both triple laws have this same overlap marginal. Padding and subtracting gives \(Q\) entry by entry: each overlap diagonal is \(8/3+8/3-7/3=3\), and the induced overlap entry is \(-1/3-1/3+2/3=0\). The remaining edges retain weight \(-1\). The determinants are \(15,15,5\), respectively, so the glued normalization gives \(\det Q=15\cdot15/5=45\), agreeing with its eigenvalues \(1,3,3,5\). This uses one separator of a non-chordal cycle; it does not assert that arbitrary edge laws on that cycle glue.
Example. Compatible edge laws with no global extension [fdip-0067]AGENTDRAFTED
- November 1, 2026
Example. Compatible edge laws with no global extension [fdip-0067]AGENTDRAFTED
- November 1, 2026
On the four-cycle \(0,1,2,3,0\), prescribe centered Gaussian edge laws with unit variances and correlations \[\rho _{01}=\rho _{12}=\rho _{23}=\frac 9{10}, \qquad \rho _{30}=-\frac 9{10}.\] Each edge covariance has eigenvalues \(1/10,19/10\), hence is positive definite. All overlap singleton laws are \(N(0,1)\). Nevertheless there is no global positive-semidefinite covariance matrix with these entries, and therefore no global Gaussian extension.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
In any joint law with these second moments, \[\|\phi _0-\phi _3\|_{L^2}=\sqrt {19/5}, \qquad \|\phi _i-\phi _{i+1}\|_{L^2}=\sqrt {1/5} \quad (i=0,1,2).\] But the first difference is the sum of the three consecutive differences. The triangle inequality would give \(\sqrt {19/5}\le 3\sqrt {1/5}\), contradicting \(19>9\). Any proposed positive-semidefinite covariance is a Gram matrix of real vectors and obeys the same norm inequality. Thus the obstruction already rules out semidefinite completion, without a nondegeneracy assumption.
The angular description gives another view of the same obstruction. Unit Gram vectors have consecutive angles \(\alpha =\arccos (9/10)\) and endpoint angle \(\pi -\alpha \). For unit vectors with successive angles \(\beta ,\gamma \) and \(\beta +\gamma \le \pi \), orthogonal decomposition along the middle vector and Cauchy–Schwarz give \[\langle u,w\rangle \ge \cos \beta \cos \gamma -\sin \beta \sin \gamma =\cos (\beta +\gamma ).\] Since arccosine decreases, the endpoint angle is at most \(\beta +\gamma \). If the sum exceeds \(\pi \), that bound is automatic. Iteration gives endpoint angle at most \(3\alpha \). But \(\alpha <\pi/4\), because \(9/10>1/\sqrt 2\); hence \(3\alpha <\pi -\alpha \), again a contradiction.
This example concerns the presheaf of laws on the edge cover: agreement on every overlap does not ensure existence. It is a concrete non-chordal obstruction of the kind distinguished by [grone1984positive, Theorem 7, p. 120]. It does not say that all data on a non-chordal graph fail to extend; the global four-cycle law in Example [fdip-006B] supplies data that do extend.
Theorem. Chordal Gaussian gluing along a junction tree [fdip-0068]AGENTDRAFTED
- November 1, 2026
Theorem. Chordal Gaussian gluing along a junction tree [fdip-0068]AGENTDRAFTED
- November 1, 2026
A clique is a vertex subset whose distinct vertices are pairwise adjacent; a maximal clique is inclusion-maximal. A finite simple graph \(\Gamma \) on \(V\) is chordal if it has no induced cycle of length at least 4. Suppose centered positive-definite Gaussian laws \(\mu _K\) on its maximal cliques agree on every overlap. Then there is a unique centered positive-definite Gaussian law with these clique marginals that is Markov with respect to \(\Gamma \). Uniqueness is asserted within that Markov class.
The maximal cliques admit a junction tree: a tree \(\mathcal T\) whose nodes are the maximal cliques, such that the nodes containing any given vertex form a connected subtree. This is the running-intersection property. Write \(S_e=K\cap K'\) for the separator on an edge \(e=KK'\) and \(p_{S_e}\) for its common marginal density. Empty separators have density one. The glued law and precision are \[p(\phi )=\frac {\prod _Kp_K(\phi _K)} {\prod _{e\in E(\mathcal T)}p_{S_e}(\phi _{S_e})},\] \[Q=\sum _K\operatorname {pad}_K(\Lambda _K) -\sum _{e\in E(\mathcal T)} \operatorname {pad}_{S_e}(\Lambda _{S_e}).\] Separator terms are counted once per tree edge, including repetitions of the same vertex subset. For \(V=\varnothing \) the law is the unit mass and both products are empty.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
We first justify the finite junction-tree construction. A vertex is simplicial when its neighbors form a clique. Every noncomplete chordal graph has two nonadjacent simplicial vertices. Here is an induction proof. In the connected case choose nonadjacent vertices \(a,b\) and an inclusion-minimal separator \(S\). Let \(C_a,C_b\) be their components in \(\Gamma \setminus S\). Minimality implies that each \(s\in S\) has a neighbor in both components: otherwise restoring that \(s\) would still leave \(a,b\) separated. If nonadjacent \(x,y\) belonged to \(S\), choose shortest \(x\)-to-\(y\) paths with internal vertices in \(C_a\) and in \(C_b\). Each path has no chord, and there are no edges between their interiors. Their union would be an induced cycle of length at least 4. Thus \(S\) is a clique.
Each induced graph \(C_a\cup S\) and \(C_b\cup S\) is smaller and chordal. If one is complete, any vertex in its component is simplicial. Otherwise induction gives two nonadjacent simplicial vertices; at most one lies in the clique \(S\), so choose one outside \(S\). Its full-graph neighbors still lie in that same induced graph, so it is simplicial in \(\Gamma \). The two choices are nonadjacent. In a disconnected graph choose a simplicial vertex in each of two components by the same induction; complete components pose no problem. Complete graphs have every vertex simplicial. This proves the assertion and allows repeated deletion of a simplicial vertex, a perfect elimination order.
Induct on that deletion to construct the clique tree. Remove a simplicial vertex \(v\), and write \(N\) for its neighbor clique. Unless no vertices remain, \(N\) lies in a maximal clique \(C\) of the remaining graph; when \(N=\varnothing \), choose any such \(C\). If \(N=C\), replace node \(C\) in its clique tree by \(C\cup \{v\}\). If \(N\subsetneq C\), attach \(N\cup \{v\}\) as a new leaf at \(C\). These are precisely the changes to the maximal cliques. In either case the nodes containing each old vertex remain connected, while \(v\) occurs only in the new node. A one-vertex graph starts the induction. Connecting different graph components in this way uses empty separators. This proves the required running-intersection property. The perfect-elimination characterization is also stated in [grone1984positive, Theorem 6, p. 119].
Now remove a leaf clique \(K\) of \(\mathcal T\) with neighbor \(C\) and separator \(S=K\cap C\). Running intersection says that \(A=K\setminus S\) occurs in no other clique, and that \(K\)'s intersection with the union of the remaining cliques is exactly \(S\). By induction glue the remaining clique laws; a one-clique tree starts with its prescribed law. The remaining law's marginal on \(S\) is the prescribed one, since it has the prescribed law on \(C\). The two-law theorem then glues in \(\mu _K\) by multiplication by \(p_K/p_S\). This proves normalization, positive definiteness, all clique marginals and the density formula. The precision formula follows at each step. Every nonzero summand is supported on a clique, so the precision is zero on all nonedges: the constructed law is Markov.
For uniqueness, \(S\) separates \(A\) from the remaining vertices outside \(S\): an edge out of \(A\) would belong to a maximal clique, but no other clique contains its endpoint in \(A\). Any Markov extension therefore factors across this separator by Theorem [fdip-0065]. Its marginal after removing \(A\) is again Markov for the induced remaining graph. Indeed the Schur correction from eliminating \(A\) is supported only on \(S\times S\), and \(S\) is a clique, so it creates no entry on a nonedge. Induction makes that remaining marginal unique; the separator factorization then makes the full law unique.
The positive-definite completion theorem of [grone1984positive, Theorem 7, p. 120, proof pp. 121–122] characterizes chordal graphs by existence for every compatible positive clique specification. The proof above additionally constructs the Markov extension and proves uniqueness within that class. Bare completion existence alone does not assert that all extensions are identical. Even for two isolated vertices, Example [fdip-006A] has many positive completions and exactly one Markov completion.
Remark. What the gluing theorem establishes about descent [fdip-0069]AGENTDRAFTED
- November 1, 2026
Remark. What the gluing theorem establishes about descent [fdip-0069]AGENTDRAFTED
- November 1, 2026
The presheaf of Gaussian laws has an explicit domain, restriction maps and overlap compatibility. On the finite-subset poset with covers given by unions, it is not a sheaf: the two-singleton cover has non-unique extensions, and the four-cycle edge cover has compatible data with no extension. These are separate failures of uniqueness and existence.
The chordal theorem gives a precise replacement on a specified clique cover. It chooses the unique extension satisfying that graph's Markov condition and supplies its density and precision. A different graph or a different collection of local laws is a different problem. This does not turn fixed-graph Markov laws into a presheaf closed under every marginal restriction; Schur elimination can introduce precision edges.
The earlier factorization comparison separates scalar factorization, functorial factorization, localization and descent. The present result adds a concrete finite local-to-global theorem for laws, but no descent data for the objects and arrows of the background groupoid. A stack would require a specified site, a category fibred over it, sheaves of morphisms and effective object descent [stacks2017stacks, Definition 8.4.1], Tag 0268. No such stack assertion follows from the density gluing formula; stack-level gluing of background objects remains an additional question.
Connections, holonomy and twisted operators [fdip-006C]AGENTDRAFTED
- November 1, 2026
Connections, holonomy and twisted operators [fdip-006C]AGENTDRAFTED
- November 1, 2026
If local field frames can differ, how are neighboring values compared? An ordinary edge difference compares two values in the same field space. A connection first transports one endpoint value to the other. The resulting positive precision depends on this extra background data. Changing frames at the vertices changes its matrix by an isometry; transport around a cycle retains information that vertex frames cannot remove.
A spanning tree reduces this information to finitely many holonomies. For a complex line on a cycle, the determinant can then be computed exactly. A nontrivial twist can remove the constant zero mode, and the normalized complex Gaussian gives an explicit holonomy action on a supplied circle. Antiperiodic spatial differences provide a related example: exact kernel dimensions change, while the additional low-energy branches of the centered symbol remain.
Definition. A connection background and its positive precision [fdip-006D]AGENTDRAFTED
- November 1, 2026
Definition. A connection background and its positive precision [fdip-006D]AGENTDRAFTED
- November 1, 2026
Fix a finite or compact Hausdorff group \(G\) and a finite-dimensional real or complex representation \(\rho :G\to \operatorname {GL}(F)\), continuous in the compact case. Supply a positive inner product for which \(\rho \) is orthogonal or unitary. If necessary, start from any positive inner product and average it: \[\langle x,y\rangle _G =\int _G\langle \rho (g)x,\rho (g)y\rangle _0\,dg.\] Here \(dg\) is normalized right Haar measure; for a finite group it is the uniform average. Haar existence and inversion from left to right are given in [gleason2010haar, Theorem 4.3, pp. 6–9; Proposition 4.1, pp. 4–5]. Compactness makes its nonzero total mass finite, allowing normalization. Right invariance gives invariance of the displayed pairing. The integrand is continuous and strictly positive for \(x=y\ne 0\), so the average is positive. The invariant metric is part of the data used below.
On a finite incidence presentation, a connection assigns \(U_e\in G\) to every chosen oriented edge. Reversing that edge assigns \(U_{\bar e}=U_e^{-1}\). Set \(H=F^V\) and \(K=F^E\), with the sums of the supplied fiber inner products. Write \(U_e\) also for \(\rho (U_e)\) in operator formulas. For scalar weights \(w_e>0\) and mass \(m>0\), define \[\begin {aligned} (d_Uf)(e)&=f(h(e))-U_ef(s(e)),\\ W&=\operatorname {diag}(w_eI_F),\\ L_U&=d_U^*Wd_U,\qquad Q_U=L_U+m^2I_H. \end {aligned}\] The adjoint uses these declared inner products. Directly, \[\langle f,Q_Uf\rangle =\sum _e w_e\|f(h(e))-U_ef(s(e))\|^2+m^2\|f\|^2.\] Thus \(Q_U\ge m^2I_H>0\). This is the unitary connection version of the difference energy; the adjoint qualification is also explicit in [kenyon2011spanning, Section 3.3, p. 6].
At \(m=0\), the same sum shows \[\ker L_U=\ker d_U =\{f:f(h(e))=U_ef(s(e))\text { for every }e\}.\] Its elements are called parallel sections. The unpinned massless Gaussian is normalizable exactly when this space is zero: then \(L_U\) is positive definite; otherwise the density is constant along a nonzero kernel direction and its integral diverges. This is separate from the pinned construction. Nontrivial group holonomy need not eliminate all parallel vectors in a higher-dimensional or nonfaithful representation.
Mathlib's LinearMap.ker_adjoint_comp_self gives
\(\ker (A^*A)=\ker A\) for finite-dimensional inner-product spaces.
Apply it to \(A=W^{1/2}d_U\); positive weights make \(W^{1/2}\)
invertible. This supports the kernel identity, not the connection,
holonomy or normalizability assertions.
Proposition. Gauge covariance and transport of selected laws [fdip-006E]AGENTDRAFTED
- November 1, 2026
Proposition. Gauge covariance and transport of selected laws [fdip-006E]AGENTDRAFTED
- November 1, 2026
For a connection background, the gauge group \(G^V\) changes the frame independently at each vertex. For \(g=(g_v)_{v\in V}\), define \[\begin {aligned} (gU)_e&=g_{h(e)}U_eg_{s(e)}^{-1},\\ (G_Vf)_v&=\rho (g_v)f_v,\\ (G_Ea)_e&=\rho (g_{h(e)})a_e. \end {aligned}\] Then \[\begin {aligned} d_{gU}G_V&=G_Ed_U,\\ Q_{gU}&=G_VQ_UG_V^{-1},\\ \det Q_{gU}&=\det Q_U. \end {aligned}\] In particular, the massive spectra and Gaussian normalizers are gauge invariant.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
On an edge with endpoints \(s,h\), \[\begin {aligned} (d_{gU}G_Vf)(e) &=\rho (g_h)f_h-\rho (g_hU_eg_s^{-1})\rho (g_s)f_s\\ &=\rho (g_h)(f_h-\rho (U_e)f_s). \end {aligned}\] This proves the first identity. Both \(G_V\) and \(G_E\) are isometries, and scalar weights imply \(G_E^*WG_E=W\). Taking adjoints in \(d_{gU}=G_Ed_UG_V^{-1}\) therefore gives \[d_{gU}^*Wd_{gU}=G_Vd_U^*Wd_UG_V^{-1}.\] The mass term commutes with \(G_V\). Multiplicativity of the determinant gives its invariance. The same isometry preserves real Euclidean volume, or the real volume underlying a complex Hermitian space, so changing variables also preserves the corresponding Gaussian integral.
For a fixed incidence presentation, \(U\mapsto gU\) is a group action: \(g_2(g_1U)=(g_2g_1)U\). Its action groupoid has connections as objects and gauge transformations as arrows. If a selector is included, use an orthogonal projector \(P\) on real \(H\), or a complex-linear orthogonal projector on complex \(H\), and transport it by \[P'=G_VPG_V^{-1}.\] The identity, composition and inverse obey this equation by conjugation. Together with relabelings that carry the connection values, these are the connection counterparts of selected-background arrows. The earlier scalar backgrounds and relabeling arrows are recovered with \(F=\mathbb R\), \(G=\{1\}\) and their original selector rank condition.
On the selected space \(X=\operatorname {im}P\), the compressed inverse is \(C_P=(PQ_U^{-1}P)|_X\). The restriction \(G_X:X\to \operatorname {im}P'\) satisfies \[C_{P'}=G_XC_PG_X^{-1}.\] Indeed insert the three conjugation identities for \(P'\), \(Q_{gU}^{-1}\) and \(P'\). Inversion transports the selected precision. For real fields this is exactly the selected Gaussian transport; for complex fields the Gaussian convention is specified in Example [fdip-006I].
Unitarity is essential for this argument. A nonorthogonal matrix representation with an unchanged Euclidean metric need not satisfy \(G_E^*WG_E=W\); changing connection matrices alone would then fail to produce the asserted conjugacy.
Theorem. Graph connections are classified by holonomy [fdip-006F]AGENTDRAFTED
- November 1, 2026
Theorem. Graph connections are classified by holonomy [fdip-006F]AGENTDRAFTED
- November 1, 2026
Let \(\Gamma \) be a finite connected graph with chosen edge orientations and root \(o\). For a path traversing \(e_1,\ldots ,e_k\), use inverse edge values when traversing backwards and define its holonomy by \[U_{e_k}\cdots U_{e_1}.\] Thus the rightmost factor transports first. Use the same composition convention for loops: \(\beta \alpha \) first traverses \(\alpha \) and then \(\beta \). The gauge classes of \(G\)-valued connections are \[\operatorname {Hom}(\pi _1(\Gamma ,o),G)/G \;\cong \;G^{b_1}/G,\qquad b_1=|E|-|V|+1,\] where \(G\) acts by simultaneous conjugation. The second identification depends on a spanning tree and orientations of the remaining edges. This classifies group-valued connections, not their possibly nonfaithful representation images or the spectra of their precisions.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Choose a spanning tree \(T\). Each vertex \(v\) has a unique tree path from \(o\); let \(t_v\in G\) be its transport, with \(t_o=1\). Use the gauge \(g_v=t_v^{-1}\). If a tree edge runs from \(s\) to \(h\), its path transports satisfy \(t_h=U_et_s\), with the equivalent inverse identity when the rooted path traverses the edge backwards. Hence \[(gU)_e=t_h^{-1}U_et_s=1\qquad (e\in T).\] Every connection therefore has a representative with all tree values one. The remaining \(|E|-|T|=b_1\) edge values are unrestricted.
A gauge transformation carrying one such representative to another satisfies \(g_hg_s^{-1}=1\) on every tree edge. Tree connectivity forces all \(g_v\) to equal one element \(a\in G\). It conjugates every remaining edge value by \(a\). Conversely every simultaneous conjugation comes from this constant gauge. This proves the classification by \(G^{b_1}/G\), including the case of a tree, where \(b_1=0\).
Traversing a path and then its inverse gives cancelling group factors, so transport is unchanged by removing backtracking. The loops that run from \(o\) through the tree to the source of a non-tree edge, traverse it and return through the tree are a free basis of \(\pi _1(\Gamma ,o)\). This is [hatcher2002algebraic, Proposition 1A.2 and its proof, pp. 84–85]: contract the tree to obtain a wedge of \(b_1\) circles. Assigning arbitrary values to this free basis gives every group homomorphism. In tree gauge these values are precisely the non-tree edge values. A general gauge conjugates each rooted loop holonomy by \(g_o\), proving the first identification as well.
With two-cells attached, call a connection flat when the ordered holonomy around every attaching boundary is the identity in \(G\). Equivalently the graph homomorphism kills the normal subgroup generated by those boundaries. It therefore factors through the fundamental group of the resulting space. A representation \(\rho \) can send a nonidentity group element to the identity operator; operator flatness alone is therefore insufficient when \(\rho \) is nonfaithful.
In the representation on \(F\), a parallel section is determined by its root value \(x\in F\). Tree transport defines its other values, and each non-tree edge condition says that its rooted holonomy fixes \(x\). Consequently evaluation at \(o\) identifies the space of parallel sections with the common fixed space of the holonomy representation. This proves the massless-kernel criterion of Definition [fdip-006D] in terms of cycle data.
Theorem. Determinants of a twisted cycle [fdip-006G]AGENTDRAFTED
- November 1, 2026
Theorem. Determinants of a twisted cycle [fdip-006G]AGENTDRAFTED
- November 1, 2026
Let \(C_n\), \(n\ge 3\), have vertices \(0,\ldots ,n-1\) and edges \(j\to j+1\) modulo \(n\). Take a complex line with unitary connection, positive weights \(w_j\), and total oriented holonomy \(u=\prod _jU_j=e^{i\theta }\). For \(L_\theta =d_U^*Wd_U\), \[\det L_\theta =\left (\prod _jw_j\right )(2-2\cos \theta ).\] For unit weights and \(c\ge 0\), let \(\omega \ge 0\) be determined by \(2\cosh \omega =2+c\). Then \[\det (cI+L_\theta )=2\cosh (n\omega )-2\cos \theta .\] The first formula is the cycle case of the weighted line-bundle matrix-tree formula, [kenyon2011spanning, Theorem 5, Section 7.1, p. 13]. Its unweighted precursor is [kenyon2011spanning, Theorem 1, p. 7]. Both cycle identities are proved directly below.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Use Theorem [fdip-006F] to set \(U_0=\cdots =U_{n-2}=1\) and \(U_{n-1}=u\). The square incidence matrix has row equations \(f_{j+1}-f_j\) for \(j<n-1\) and \(f_0-uf_{n-1}\) for the last row. In its determinant expansion the only nonzero permutations choose all source entries or all head entries: choosing one head entry forces the next row to choose its head entry, and so around the cycle. Their signed sum is \(1-u\) up to an overall sign. Hence \[\det (d_U^*Wd_U) =|\det d_U|^2\det W =|1-u|^2\prod _jw_j.\] Since \(|1-e^{i\theta }|^2=2-2\cos \theta \), this proves the first formula, including trivial holonomy.
For unit weights introduce the unitary shift \[(T_\theta f)_j=\begin {cases} f_{j+1},&j<n-1,\\ u^{-1}f_0,&j=n-1. \end {cases}\] The last edge difference is \(u(T_\theta f-f)_{n-1}\), so its modulus is unchanged. Thus \(L_\theta =2I-T_\theta -T_\theta ^*\). The seam convention is \(f_n=u^{-1}f_0\); its modes and eigenvalues are \[\begin {aligned} p_k&=(2\pi k-\theta )/n,\qquad 0\le k<n,\\ f_k(j)&=n^{-1/2}e^{ip_kj},\\ L_\theta f_k&=(2-2\cos p_k)f_k. \end {aligned}\] Distinct modes are orthogonal because their ratios are nontrivial \(n\)-th roots of unity; the finite geometric sum vanishes. There are \(n\) modes, so they form a complete basis.
Put \(r=e^\omega \) and \(z_k=e^{ip_k}\). The numbers \(z_k\) are all roots of \(z^n=u^{-1}\). Since \[c+2-z-z^{-1}=r^{-1}(r-z)(r-z^{-1}),\] the product of the eigenvalues is \[\begin {aligned} \det (cI+L_\theta ) &=r^{-n}(r^n-u^{-1})(r^n-u)\\ &=r^n+r^{-n}-u-u^{-1}\\ &=2\cosh (n\omega )-2\cos \theta . \end {aligned}\] The computation remains valid at \(c=0\), when \(r=1\).
Example. An antiperiodic four-cycle has no parallel line section [fdip-006H]AGENTDRAFTED
- November 1, 2026
Example. An antiperiodic four-cycle has no parallel line section [fdip-006H]AGENTDRAFTED
- November 1, 2026
Give the unit four-cycle total holonomy \(u=-1\), or \(\theta =\pi \). In the tree gauge, three links are one and the final link is minus one. The cycle modes have momenta \(-\pi /4,\pi /4,3\pi /4,5\pi /4\), so \[\operatorname {spec}L_\pi =\{2-\sqrt 2,2-\sqrt 2,2+\sqrt 2,2+\sqrt 2\}.\] All 4 eigenvalues are positive, and \(\det L_\pi =((2-\sqrt 2)(2+\sqrt 2))^2=4\).
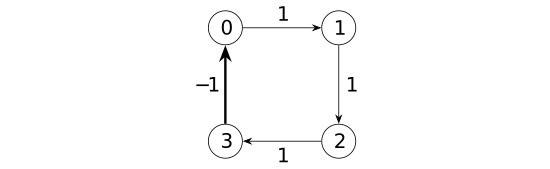
The arrows show the chosen orientation; labels are connection values, not edge weights, which are all one. The thick edge carries the remaining holonomy after the other three form a tree. A parallel section would have \(f_0=f_1=f_2=f_3\) along those tree edges and \(f_0=-f_3\) along the last edge, forcing zero. Thus the massless complex Gaussian exists without a pin. With trivial holonomy the constant line is a kernel instead. This is a change of background connection, distinct from conditioning a scalar Gaussian on pinned values.
Example. A normalized complex holonomy action on the circle [fdip-006I]AGENTDRAFTED
- November 1, 2026
Example. A normalized complex holonomy action on the circle [fdip-006I]AGENTDRAFTED
- November 1, 2026
Use the supplied unit-circle mesh, now with complex fields and total holonomy \(e^{i\theta }\). On \(\mathbb C^n\), take \[\langle z,w\rangle _n=\frac 1n\sum _j\overline {z_j}w_j, \qquad Q_{n,\theta }=n^2L_\theta +\mu I,\qquad \mu >0.\] Here \(L_\theta \) is the unit-weight twisted cycle, \(n\ge 3\), and the same factor \(n^2\) fixes the circle length scale. Let \(d\operatorname {vol}_n\) be the real volume induced by this Hermitian pairing. If \(z_j=x_j+iy_j\), then \[d\operatorname {vol}_n=n^{-n}\prod _jdx_j\,dy_j.\] Indeed \(z\mapsto z/\sqrt n\) is an orthonormal coordinate change in complex dimension \(n\), hence real dimension \(2n\).
Choose the complex Gaussian convention \[\begin {aligned} Z_n(\theta )&=\pi ^{-n}\int _{\mathbb C^n} e^{-\langle z,Q_{n,\theta }z\rangle _n} \,d\operatorname {vol}_n(z),\\ W_n(\theta )&=-\log Z_n(\theta ). \end {aligned}\] Unitary diagonalization gives one factor per eigenvalue \(\lambda >0\). Polar coordinates evaluate it: \[\begin {aligned} \pi ^{-1}\int _{\mathbb R^2}e^{-\lambda (x^2+y^2)}dx\,dy &=2\int _0^\infty e^{-\lambda r^2}r\,dr\\ &=\lambda ^{-1}. \end {aligned}\] Therefore \[Z_n(\theta )=(\det _{\mathbb C}Q_{n,\theta })^{-1}, \qquad W_n(\theta )=\log \det _{\mathbb C}Q_{n,\theta }.\] This complex convention has no factor \(1/2\) in the determinant action; the earlier real Gaussian action uses a different exponent and real field dimension.
Since \(Q_{n,\theta }=n^2(L_\theta +\mu n^{-2}I)\), define the explicitly subtracted finite action by \[\widetilde W_n(\theta )=W_n(\theta )-2n\log n.\] The cycle determinant gives \[\begin {aligned} \widetilde W_n(\theta ) &=\log (2\cosh (n\omega _n)-2\cos \theta ),\\ 2\cosh \omega _n&=2+\mu /n^2,\qquad \omega _n\ge 0. \end {aligned}\] Thus the removed term is independent of holonomy; it is part of the stated normalization, not a finite determinant omitted from the formula.
The identity \(\cosh \omega -1=2\sinh ^2(\omega /2)\) gives \(\omega _n=2\operatorname {arsinh}(\sqrt {\mu }/(2n))\). For \(t>0\), integrate the derivative \((\operatorname {arsinh}t)'=(1+t^2)^{-1/2}\) to obtain \[\frac 1{\sqrt {1+t^2}} \le \frac {\operatorname {arsinh}t}{t}\le 1.\] Consequently \(n\omega _n\to \sqrt \mu \). The positive limiting argument of the logarithm is at least \(2\cosh \sqrt \mu -2>0\), so \[\widetilde W_n(\theta )\longrightarrow W(\theta )=\log (2\cosh \sqrt \mu -2\cos \theta ).\] This is a direct limit of the normalized finite determinants, beyond the separate fixed-mode comparison; no interchange of an infinite product is used.
For \(\mu >0\), \(W(\theta )\) is minimized exactly at trivial holonomy \(\theta =0\) modulo \(2\pi \), since \(\cos \theta \le 1\). Equivalently the integrated matter factor \(e^{-W}\) is largest there. At \(\mu =0\) and nontrivial holonomy the same finite calculation gives \(W(\theta )=\log (2-2\cos \theta )\). At trivial holonomy there is a zero mode: the unpinned Gaussian integral diverges and this determinant action is undefined. Its formal logarithm of zero is not a normalized Gaussian action. The circle, its scale and the connection remain supplied data.
Example. Antiperiodic spatial Dirac modes [fdip-006J]AGENTDRAFTED
- November 1, 2026
Example. Antiperiodic spatial Dirac modes [fdip-006J]AGENTDRAFTED
- November 1, 2026
Keep the spatial Clifford module \(S=(\mathbb C^2)^{\otimes d}\), with \(\dim _{\mathbb C}S=2^d\), and periods \(N_j\ge 3\). Give scalar fields on the fundamental box \(0\le x_j<N_j\) the antiperiodic extension \[f(x+N_je_j)=-f(x)\qquad (1\le j\le d).\] The forward shift \(T_j^-\) uses this extension at a seam. It is a signed permutation, hence unitary in the counting pairing; shifts in different coordinates commute. They act on the lattice factor only, so they commute with the Clifford matrices on \(S\). Define \[D^- =\sum _{j=1}^d\gamma _j\otimes \frac {T_j^--(T_j^-)^{-1}}2.\] These are fixed flat line twists, each with holonomy minus one.
For labels \(0\le r_j<N_j\), set \[p_j=\frac {(2r_j+1)\pi }{N_j},\qquad \chi _r(x)=\left (\prod _jN_j\right )^{-1/2} e^{i\sum _jp_jx_j}.\] The exponential obeys the declared antiperiodic extension. Differences of two allowed momenta are periodic Fourier momenta, so the same geometric-sum proof as Theorem [fdip-000S] makes these functions a complete orthonormal basis of fields on the box. On its momentum block, \[\begin {aligned} D^-(p)&=i\sum _j\gamma _j\sin p_j,\\ -D^-(p)^2&=\left (\sum _j\sin ^2p_j\right )I_S. \end {aligned}\] The square follows from the Clifford anticommutators and commuting coordinate shifts, exactly as in the untwisted calculation.
A block is zero precisely when every \(\sin p_j=0\); otherwise its inverse is \(-D^-(p)/(\sum _j\sin ^2p_j)\). Since \(0<p_j<2\pi \), the only possible zero is \(p_j=\pi \), which requires \(2r_j+1=N_j\). It occurs once when \(N_j\) is odd and never when it is even. Hence \[\dim _{\mathbb C}\ker D^-= \begin {cases} 2^d,&\text {all periods are odd},\\ 0,&\text {at least one period is even}. \end {cases}\] For two directions the comparison with Proposition [fdip-000T] is \[\begin {array}{c|ccc} (N_1,N_2)&(4,4)&(4,3)&(3,3)\\\hline \dim \ker D&16&8&4\\ \dim \ker D^-&0&0&4 \end {array}\] These are dimensions in the specified reducible module, not physical species or chirality counts.
The twist changes exact zeros without removing the centered symbol's extra low-energy branches. For large \(N_j\), an allowed momentum lies within \(\pi /N_j\) of each corner coordinate \(0\) or \(\pi \), with distance to \(0\) understood modulo \(2\pi \). Thus \(|\sin p_j|\le \pi /N_j\) near every such corner. After restoring a fixed-length mesh spacing \(a_j=L_j/N_j\), the corresponding \(|\sin p_j|/a_j\) is bounded by \(\pi /L_j\); branches near the \(\pi \) corners remain at finite energy alongside the branch near zero. This does not say that the rescaled antiperiodic eigenvalues tend to zero at fixed circle lengths. The additional branches are the centered-difference doubling problem, whose sine symbol is discussed in [wingate2025lattice, Section 9.1, Equations (9.6)–(9.7), p. 20]. A boundary twist alone does not supply its Wilson-operator remedy.
Remark. Fixed connections and dynamical fields [fdip-006K]AGENTDRAFTED
- November 1, 2026
Remark. Fixed connections and dynamical fields [fdip-006K]AGENTDRAFTED
- November 1, 2026
A connection in this chapter is fixed background data. Gauge transformations compare its descriptions; taking their quotient does not prescribe a probability law on connections. The holonomy action integrates matter while retaining the connection as a parameter. To make the connection dynamical one must also specify its integration measure and action, and then integrate or sum over connection configurations.
The earlier induced action on weighted graphs likewise keeps the weights fixed. One could subsequently promote them to integration variables, but that is an additional model choice. Neither the fixed-weight action nor the present connection construction makes weights dynamical or supplies gravitational dynamics. A prescribed circle limit and a twisted spatial Dirac operator also do not supply a time direction, reflection positivity or Lorentzian reconstruction. These distinctions remain part of the open physical interfaces.
Finite gauge fields and an exact torus law [fdip-006L]AGENTDRAFTED
- November 1, 2026
Finite gauge fields and an exact torus law [fdip-006L]AGENTDRAFTED
- November 1, 2026
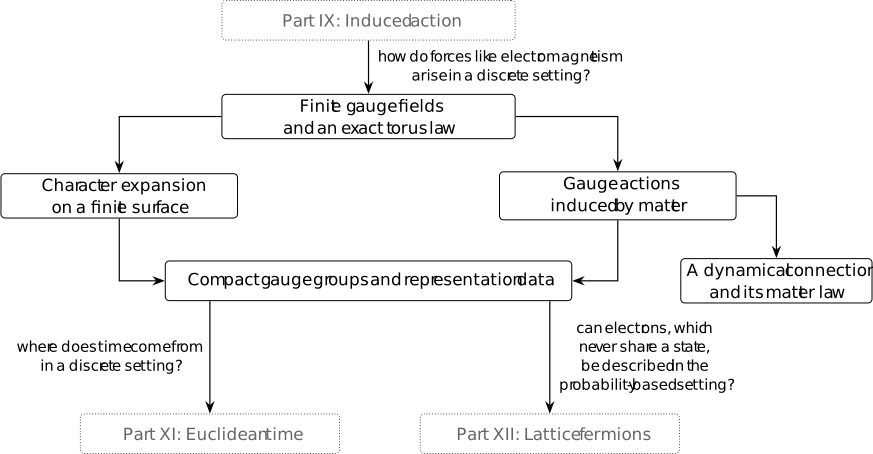
How can the transports used to compare neighboring fields themselves fluctuate? A connection background assigns a fixed transport to each edge; it is already gauge-field data. A law on those transports makes them dynamical. We now sum over them as field variables, while keeping the graph, its square faces and the group fixed. The faces are extra incidence data: the earlier graph alone does not specify them. A chosen unitary representation gives a Wilson action and a finite probability law with an explicit counting-measure convention.
Matter integration already distinguishes connections in the massive complex Gaussian on a supplied circle. Its normalized holonomy action \(W\) is minimized at trivial holonomy, so the integrated matter factor \(e^{-W}\) is largest there. That comparison leaves the circle and connection supplied. The finite law here is a further choice; transport alone does not derive a force such as electromagnetism.
Gauge averaging first determines which parts of an observable can contribute to its expectation. For the two-element group on a square torus, all plaquette signs can then be counted exactly. One global constraint and two remaining cycle holonomies account for the partition function's normalization. The resulting loop formula gives a pure-gauge area law in two dimensions; no matter field is included in that result.
Definition. Square faces on a finite graph [fdip-006M]AGENTDRAFTED
- November 1, 2026
Definition. Square faces on a finite graph [fdip-006M]AGENTDRAFTED
- November 1, 2026
A finite cubical 2-complex, in the square-cell convention used here, consists of a finite incidence presentation \((V,E,s,h)\), a finite set \(\mathcal P\) of squares, and a specified four-edge attaching walk for each square. Choose one orientation for each edge and one boundary orientation and starting vertex for each square. Its walk is \[\partial p=(e_{p,1}^{\epsilon _{p,1}},\ldots , e_{p,4}^{\epsilon _{p,4}}),\qquad \epsilon _{p,j}\in \{1,-1\},\] where an exponent \(-1\) means traversal against the chosen edge orientation. Consecutive endpoints match, including the last to the first.
Starting from the one-dimensional realization, attach one copy of \([0,1]^2\) for each \(p\), mapping its 4 sides to the specified traversed edges, and use the quotient topology. Boundary vertices or sides may be identified in this presentation, as in periodic quotients; no regularity or nonpositive-curvature condition is imposed. No higher-dimensional cubes are supplied. The squares and their attaching maps are additional data, just as the filled face is additional data in the triangle comparison.
The main example is the square torus with periods \(N_1,N_2\ge 3\). Its vertices are \[V=(\mathbb Z/N_1\mathbb Z)\times (\mathbb Z/N_2\mathbb Z).\] There are horizontal edges \(a_{x,y}:(x,y)\to (x+1,y)\) and vertical edges \(b_{x,y}:(x,y)\to (x,y+1)\), with indices read modulo the periods. The square at \((x,y)\) has boundary walk \[a_{x,y}\,b_{x+1,y}\,a_{x,y+1}^{-1}\,b_{x,y}^{-1}.\] This written order is the order of traversal. Put \[n=|V|=N_1N_2,\qquad |E|=2n,\qquad P=|\mathcal P|=n.\] The realization is the usual square grid on a torus. The periods ensure that each square has 4 distinct vertices and sides, although periodic identifications occur globally.
Definition. Plaquette transport and Wilson loops [fdip-006N]AGENTDRAFTED
- November 1, 2026
Definition. Plaquette transport and Wilson loops [fdip-006N]AGENTDRAFTED
- November 1, 2026
Let \(G\) be a finite group on a square complex. A connection is \(U\in G^E\), with \(U_{\bar e}=U_e^{-1}\) on a reversed edge. For a traversed path \(C=(e_1^{\epsilon _1},\ldots ,e_k^{\epsilon _k})\), define \[U_C=U_{e_k}^{\epsilon _k}\cdots U_{e_1}^{\epsilon _1}.\] The first transport acts on the right. The plaquette holonomy is \(U_p=U_{\partial p}\). The gauge group \(\mathcal G=G^V\) acts by \[(gU)_e=g_{h(e)}U_eg_{s(e)}^{-1}.\] Cancellation at successive vertices gives \[(gU)_C=g_{h(C)}U_Cg_{s(C)}^{-1}.\] For a closed path based at \(v\), this is conjugation by \(g_v\).
Choose a unitary representation \(\rho :G\to U(d)\) with \(d>0\), and let \(\chi _\rho (g)=\operatorname {Tr}\rho (g)\) be its character. The Wilson loop of a closed path is the unnormalized trace \[W_\rho (C)=\chi _\rho (U_C).\] It is gauge invariant. Changing the starting vertex conjugates the holonomy, so it does not change this trace. Reversing the path replaces \(U_C\) by \(U_C^{-1}\), hence replaces \(W_\rho (C)\) by its complex conjugate. In particular \(\operatorname {Re}W_\rho (C)\) is independent of the chosen boundary orientation. These are the transport and trace conventions of [wingate2025lattice, equations (6.14)–(6.19), pp. 7–8].
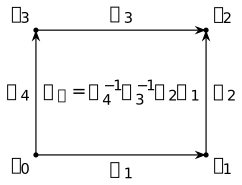
The arrows show the chosen edge orientations and the labels are connection values, not scalar weights. The boundary traversal is \[v_0\to v_1\to v_2\to v_3\to v_0.\] It uses the top and left edges backwards, accounting for both inverses.
Definition. The finite Wilson action and counting law [fdip-006O]AGENTDRAFTED
- November 1, 2026
Definition. The finite Wilson action and counting law [fdip-006O]AGENTDRAFTED
- November 1, 2026
For the finite connection data and a fixed real \(\beta \ge 0\), define the Wilson action \[S_W(U)=\beta \sum _{p\in \mathcal P} \left (1-\frac {\operatorname {Re}\chi _\rho (U_p)}d\right ).\] Since \(\rho (U_p)\) is unitary, its eigenvalues have modulus one and \(-d\le \operatorname {Re}\chi _\rho (U_p)\le d\). Thus \(S_W(U)\ge 0\). The action is gauge invariant and does not depend on starting vertices or boundary orientations.
Use unnormalized counting measure on each edge group, and therefore on \(G^E\). The partition function, probability and expectation are \[\begin {aligned} Z_W&=\sum _{U\in G^E}e^{-S_W(U)},\\ \mathbb P_W(U)&=Z_W^{-1}e^{-S_W(U)},\\ \langle F\rangle _W&=Z_W^{-1}\sum _{U\in G^E}F(U)e^{-S_W(U)}. \end {aligned}\] These finite sums have \(0<Z_W<\infty \). Matrix-valued observables are averaged entry by entry. The finite group and chosen representation are inputs to this law, alongside the square complex and \(\beta \).
The constant term in the action matters for the partition function. With \(P=|\mathcal P|\), put \[\begin {aligned} \mathcal Z(\beta ) &=\sum _{U\in G^E}\exp \left ( \frac \beta d\sum _p\operatorname {Re}\chi _\rho (U_p)\right ),\\ Z_W(\beta )&=e^{-\beta P}\mathcal Z(\beta ). \end {aligned}\] The two weights define the same normalized expectation. Replacing each edge's counting measure by uniform probability measure instead gives \(|G|^{-|E|}Z_W\); that is a different partition-function normalization, again with the same expectation. In particular \(Z_W(0)=|G|^{|E|}\). The action and expectation agree with the conventions in [wingate2025lattice, equations (6.20)–(6.21), p. 8]; that source uses normalized Haar integration for its compact-group setting, whereas the finite counting convention here is explicit.
Theorem. Finite gauge averaging [fdip-006P]AGENTDRAFTED
- November 1, 2026
Theorem. Finite gauge averaging [fdip-006P]AGENTDRAFTED
- November 1, 2026
For the finite Wilson law, define \[(\mathcal AF)(U)=\frac 1{|\mathcal G|} \sum _{g\in \mathcal G}F(gU),\qquad \mathcal G=G^V.\] Then \(\mathcal A\) projects onto gauge-invariant observables and \[\langle F\rangle _W=\langle \mathcal AF\rangle _W.\] In particular \(\langle F\rangle _W=0\) whenever \(\mathcal AF=0\). A general noninvariant observable may have a nonzero invariant part; only \(F-\mathcal AF\) is always forced to have zero expectation.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For each \(g\), the map \(U\mapsto gU\) is a bijection of \(G^E\) with inverse \(U\mapsto g^{-1}U\). Gauge invariance of the action and change of variable in a finite sum give \[\sum _U F(gU)e^{-S_W(U)}=\sum _U F(U)e^{-S_W(U)}.\] Divide by \(Z_W\) and average over \(g\). Reindexing \(g\mapsto gh\) gives \((\mathcal AF)(hU)=(\mathcal AF)(U)\). If \(F\) is already invariant then \(\mathcal AF=F\), proving \(\mathcal A^2=\mathcal A\) and the asserted range.
Let \(\sigma \) be a nontrivial irreducible complex representation of \(G\), and let \(e\) have distinct endpoints. Then \[\langle \sigma (U_e)\rangle _W=0.\] To see this, set \(R=|G|^{-1}\sum _{a\in G}\sigma (a)\). Reindexing shows that \(\sigma (b)R=R\) for every \(b\), so \(R\) maps into the fixed-vector space. It is the identity on that space. A nonzero fixed vector would span a trivial subrepresentation; irreducibility and nontriviality therefore make the fixed-vector space zero and \(R=0\). Averaging the gauge transformation at \(h(e)\) while fixing the other vertices now replaces \(\sigma (U_e)\) by \(R\sigma (U_e)=0\). The expectation is unchanged by this averaging, by the same finite change-of-variable proof. Distinct endpoints are essential here.
For a self-loop, the transformation is only conjugation. The one-loop example shows that its expectation need not vanish.
This is a direct finite averaging proof, related to
Maschke averaging. Mathlib's
Representation.isProj_averageMap proves projection onto
invariants for a finite group representation over a commutative ring
in which the group order is invertible. Over \(\mathbb C\), apply it
to the inverse-pullback representation
\((R_gF)(U)=F(g^{-1}U)\), or to \(\sigma \) above. This supports the
linear averaging step, not the Wilson probability or torus formulas.
Example. A self-loop with nonzero expectation [fdip-006T]AGENTDRAFTED
- November 1, 2026
Example. A self-loop with nonzero expectation [fdip-006T]AGENTDRAFTED
- November 1, 2026
For a self-loop \(e\), the transformation is only conjugation. In the square-cell convention, take one vertex, one loop and one square whose attaching walk traverses that loop 4 times. Use the finite Wilson law. With \(G=\{1,\omega ,\omega ^2\}\) and \(\omega =e^{2\pi i/3}\), use the one-dimensional representation \(\rho (U)=U\). Then \(U_p=U^4=U\), the gauge action is trivial, and \[\langle U\rangle _W =\frac {1-e^{-3\beta/2}}{1+2e^{-3\beta/2}}>0\qquad (\beta >0).\] Thus no general open-edge vanishing conclusion extends to self-loops.
Lemma. Plaquette signs and the two torus holonomies [fdip-006Q]AGENTDRAFTED
- November 1, 2026
Lemma. Plaquette signs and the two torus holonomies [fdip-006Q]AGENTDRAFTED
- November 1, 2026
On the square torus, let \(G=\mathbb Z_2=\{1,-1\}\) under multiplication, with \(n=|V|=P\) and \(|E|=2n\). The map sending a connection to its plaquette signs has image exactly \[\left \{(u_p)\in \{1,-1\}^{\mathcal P}:\prod _pu_p=1\right \}.\] Every such sign configuration has \(2^{n+1}\) preimages in \(G^E\). It consists of 4 gauge orbits, distinguished by two fundamental cycle holonomies.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Each edge occurs twice among the square boundaries, so \(\prod _pU_p=1\). Conversely, choose a spanning tree in the connected dual graph, whose vertices are squares and whose edges cross their shared primal edges. Root this tree and set all primal edge signs to \(1\). Process dual leaves towards the root. At each leaf, its unique remaining dual-tree edge crosses a primal edge shared with its parent. Flip that primal sign exactly when needed to give the leaf its prescribed plaquette sign, then remove the leaf. This changes only the leaf and its parent among the unprocessed squares and changes no previously fixed square. At the last square, the global product constraint forces the prescribed root sign. This constructs every even-parity plaquette pattern.
The plaquette map is a homomorphism between finite abelian groups. Multiplication by one preimage identifies its kernel with any nonempty fiber. There are \(2^{P-1}\) target patterns, hence each fiber has \[\frac {2^{|E|}}{2^{P-1}}=2^{n+1}\] elements. For a connected graph, a gauge transformation fixes an abelian connection exactly when \(g_{h(e)}=g_{s(e)}\) on every edge, that is, when all vertex values are the same. The stabilizer has two elements, so every gauge orbit has \(2^{n-1}\) elements. The fiber therefore contains \(2^{n+1}/2^{n-1}=4\) orbits.
Take a horizontal fundamental cycle in one row and a vertical one in one column. Multiply by \(-1\) every horizontal edge crossing the periodic seam from \(x=N_1-1\) to \(x=0\). Each plaquette contains zero or two such edges, so its sign is unchanged, while the horizontal cycle holonomy flips and the vertical one does not. The analogous vertical seam operation flips just the other holonomy. The two operations give 4 possibilities for these gauge-invariant signs. They are distinct gauge orbits, and the count above shows that they exhaust the 4 orbits in each plaquette fiber.
Theorem. The exact pure-gauge torus law [fdip-006R]AGENTDRAFTED
- November 1, 2026
Theorem. The exact pure-gauge torus law [fdip-006R]AGENTDRAFTED
- November 1, 2026
For the square torus, take \(G=\{1,-1\}\) in its one-dimensional sign representation and use the counting convention. With \(n=|V|=P\) and \(\beta \ge 0\), \[\begin {aligned} \mathcal Z(\beta ) &=2^{n+1}\,\frac {(2\cosh \beta )^P+(2\sinh \beta )^P}{2},\\ Z_W(\beta )&=e^{-\beta P}\mathcal Z(\beta ). \end {aligned}\] Let \(C\) be a simple contractible edge loop bounding a specified disk of \(A\) square faces, where \(0<A<P\). Put \(t=\tanh \beta \). Its Wilson loop is \(W(C)=U_C\in \{1,-1\}\), and \[\langle W(C)\rangle _W =\frac {t^A+t^{P-A}}{1+t^P}.\] The finite formula includes the complementary region through the second term.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Write \(u_p=U_p\). By the plaquette counting lemma, every pattern with \(\prod _pu_p=1\) has \(2^{n+1}\) preimages. The indicator of this constraint is \((1+\prod _pu_p)/2\). Therefore \[\begin {aligned} \mathcal Z(\beta ) &=\frac {2^{n+1}}2\sum _{u\in \{1,-1\}^{\mathcal P}} \left (1+\prod _pu_p\right )\prod _p e^{\beta u_p}\\ &=\frac {2^{n+1}}2 \left [(2\cosh \beta )^P+(2\sinh \beta )^P\right ]. \end {aligned}\] Here each unweighted one-sign sum is \(2\cosh \beta \) and each sign-weighted sum is \(2\sinh \beta \). The displayed Wilson action constant gives the formula for \(Z_W\).
Multiplying the plaquette signs inside the chosen disk cancels every interior edge twice and leaves exactly the boundary product, so \(W(C)=\prod _{p\text { inside }C}u_p\). Insert this product into the preceding constrained sum. The two terms in the unnormalized numerator, after removing the common factor \(2^{n+1}/2\), are \[\begin {aligned} &(2\sinh \beta )^A(2\cosh \beta )^{P-A},\\ &(2\cosh \beta )^A(2\sinh \beta )^{P-A}. \end {aligned}\] Divide by the corresponding partition function and then by \((2\cosh \beta )^P\). The common action constant cancels, proving the expectation formula.
Fix \(\beta >0\) and a finite disk loop while both torus periods grow, so \(A\) stays fixed and \(P\to \infty \). Then \(0<t<1\), giving \[\begin {aligned} \lim _{P\to \infty }\langle W(C)\rangle _W &=t^A=e^{-\sigma A},\\ \sigma &=-\log (\tanh \beta )>0. \end {aligned}\] This is an exact area law for this two-dimensional pure-gauge limit. It is not a claim for a matter-coupled law or for higher-dimensional lattices. At \(\beta =0\), the finite formula instead gives zero for these nonempty proper disk loops, and \(Z_W(0)=2^{2n}\).
Example. A three-by-three torus calculation [fdip-006S]AGENTDRAFTED
- November 1, 2026
Example. A three-by-three torus calculation [fdip-006S]AGENTDRAFTED
- November 1, 2026
For \(N_1=N_2=3\), there are 9 vertices, 18 edges and 9 plaquettes. The plaquette constraint permits only an even number \(k\) of negative plaquettes. There are \(\binom 9k\) such patterns and \(2^{10}=1024\) edge configurations for each pattern. The resulting numbers of edge configurations are \[\begin {array}{c|rrrrr} k&0&2&4&6&8\\\hline \text {count}&1024&36864&129024&86016&9216. \end {array}\] They sum to \(262144=2^{18}\), the number of all edge assignments.
Since \(\sum _pU_p=9-2k\), the partition polynomial is \[\begin {aligned} \mathcal Z(\beta )=1024\bigl (&e^{9\beta }+36e^{5\beta }+126e^\beta \\ &+84e^{-3\beta }+9e^{-7\beta }\bigr ),\\ Z_W(\beta )&=e^{-9\beta }\mathcal Z(\beta ). \end {aligned}\] At \(\beta =0\), this again gives \(2^{18}\). The factor \(e^{-9\beta }\) is necessary for the Wilson-action partition function even though it cancels from every normalized observable.
For \(\tanh \beta =1/2\), the exact loop formula gives \[\begin {aligned} \langle W(C_1)\rangle _W &=\frac {(1/2)+(1/2)^8}{1+(1/2)^9}=\frac {86}{171},\\ \langle W(C_2)\rangle _W &=\frac {(1/2)^2+(1/2)^7}{1+(1/2)^9}=\frac {44}{171}. \end {aligned}\] Here \(C_1\) bounds one square and \(C_2\) bounds two adjacent squares, each a simple disk boundary on this torus. These values include the finite-volume corrections; they are not yet \(t\) and \(t^2\).
Character expansion on a finite surface [fdip-006U]AGENTDRAFTED
- November 1, 2026
Character expansion on a finite surface [fdip-006U]AGENTDRAFTED
- November 1, 2026
The two-element torus law counts plaquette signs. For a noncommutative finite gauge group, irreducible characters replace those signs. Averaging each edge pairs two representation matrices; the remaining index sums count vertices. On a closed oriented surface, Euler characteristic then determines the power of each representation's dimension.
The face weight and the measure are explicit throughout. The quaternion group and the binary tetrahedral group give finite examples with the same two-dimensional spinor Wilson action. Their exact surface partition functions and one-face loop expectations depend on their different character tables. These are finite pure-gauge models; no continuum limit or matter field is assumed.
Definition. Finite surface gauge data and face weights [fdip-006V]AGENTDRAFTED
- November 1, 2026
Definition. Finite surface gauge data and face weights [fdip-006V]AGENTDRAFTED
- November 1, 2026
Let \(\Sigma \) be a connected closed oriented surface of genus \(g\), with a finite polygonal cell decomposition. Write \(V,E,\mathcal P\) for its vertices, edges and disk faces, and \(P=|\mathcal P|>0\). Each face has a nonempty cyclic boundary word. Every edge occurs exactly twice among all face boundaries, with opposite orientations; the two occurrences may belong to the same face. The link of each vertex is a circle. These surface conditions are stronger than the square-cell data: singular quotients are excluded. Loops and repeated boundary edges are allowed.
Choose one orientation per edge and a finite group \(G\). A connection is \(U\in G^E\), with the inverse assigned to a reversed traversal. Use the ordered-transport convention: if a face boundary successively traverses \(e_1^{\epsilon _1},\ldots , e_k^{\epsilon _k}\), its holonomy is \[U_p=U_{e_k}^{\epsilon _k}\cdots U_{e_1}^{\epsilon _1}.\] Orient all faces by the orientation of \(\Sigma \). Changing a starting vertex conjugates \(U_p\). A central function, or class function, is a function \(f:G\to \mathbb C\) satisfying \(f(khk^{-1})=f(h)\) for all \(h,k\in G\). It therefore defines the normalized partition sum \[Z_\Sigma (f)=\frac 1{|G|^{|E|}}\sum _{U\in G^E} \prod _{p\in \mathcal P}f(U_p).\] This uses uniform probability measure on each edge. Unnormalized counting gives \(|G|^{|E|}Z_\Sigma (f)\). A complex face weight is allowed for the algebraic identity; if \(f>0\), division by the partition sum defines a probability law.
For a fixed unitary representation \(\sigma \) of complex dimension \(d_\sigma >0\) and \(\beta \ge 0\), the Wilson action corresponds to \[f_\beta (h)=\exp \left [-\beta \left ( 1-\frac {\operatorname {Re}\chi _\sigma (h)}{d_\sigma }\right )\right ].\] The constant \(e^{-\beta }\) per face is part of this weight. For an oriented closed edge path \(C\), its normalized real Wilson loop is \[W_\sigma (C)=\frac {\operatorname {Re}\chi _\sigma (U_C)}{d_\sigma }.\] It is gauge invariant, independent of its starting vertex and unchanged by reversal. For a general central \(f\), reversal of the chosen surface orientation need not preserve the weight; the Wilson weight is inversion invariant.
Choose one unitary representative of each complex irreducible
representation, indexed by \(\widehat G\), with dimension \(d_\rho \).
The character basis gives the finite expansion
\[\begin {aligned}
f(h)&=\sum _{\rho \in \widehat G}c_\rho \chi _\rho (h),\\
c_\rho &=\frac 1{|G|}\sum _{h\in G}
f(h)\overline {\chi _\rho (h)}.
\end {aligned}\]
These coefficients are not divided by \(d_\rho \) in the expansion.
TauCeti's
TauCeti.ClassFunction.apply_eq_sum_characterPairing_mul_character
formalizes this finite class-function expansion. Its bilinear pairing
is \(|G|^{-1}\sum _h\chi _\rho (h)f(h^{-1})\); substitution by inversion
and unitarity give the displayed coefficient. This correspondence
concerns the expansion, not the surface partition theorem below.
Theorem. The finite surface character formula [fdip-006W]AGENTDRAFTED
- November 1, 2026
Theorem. The finite surface character formula [fdip-006W]AGENTDRAFTED
- November 1, 2026
For the surface data and coefficients, \[Z_\Sigma (f)=\sum _{\rho \in \widehat G} d_\rho ^{\,2-2g}\left (\frac {c_\rho }{d_\rho }\right )^P.\] The formula uses normalized counting on every edge. In particular, \(f\equiv 1\) gives \(Z_\Sigma (1)=1\); the unnormalized sum is \(|G|^{|E|}\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
First prove the required matrix orthogonality. For irreducible unitary representations \(\rho ,\tau \) and a linear map \(A:V_\tau \to V_\rho \), let \[\mathcal A(A)=\frac 1{|G|}\sum _{h\in G} \rho (h)A\tau (h)^{-1}.\] Changing the summation variable shows this is an intertwiner. Schur's lemma makes it zero when the representatives are inequivalent. For \(\rho =\tau \), it is scalar, and preservation of trace gives \(\mathcal A(A)=(\operatorname {tr}A/d_\rho )I\). Apply this to matrix units to obtain \[\frac 1{|G|}\sum _{h\in G} \rho (h)_{ij}\tau (h^{-1})_{kl} =\begin {cases} d_\rho ^{-1}\delta _{il}\delta _{jk},&\rho =\tau ,\\ 0,&\rho \ne \tau . \end {cases}\] This is a finite averaging argument; all sums below are finite.
Expand \(f\) on every face and each character as a matrix trace along the ordered boundary word. Label every face by an irreducible representation and every corner by the corresponding matrix index. An edge occurs in two face traces, once as \(\rho (U_e)\) and once as \(\tau (U_e^{-1})\). Averaging that edge gives the displayed orthogonality identity. If the adjacent faces differ, their labels must coincide for a nonzero contribution. The dual adjacency graph of a connected closed surface is connected, so one common label \(\rho \) remains on every face. A self-adjacent edge simply contracts two occurrences of this same label. Each edge contributes \(d_\rho ^{-1}\).
The two Kronecker deltas identify corner indices at the same endpoint of that edge. Around a vertex, the successive sectors form its circular link. Consequently all corners at that vertex have one common index, while no contraction equates indices at different vertices. Exactly one free index remains per vertex, contributing \(d_\rho ^{|V|}\). This also covers loops and repeated face edges: the circular link, rather than distinct face or edge names, determines the index cycle. The contribution of the common label is therefore \[c_\rho ^P d_\rho ^{|V|-|E|} =d_\rho ^{2-2g}\left (\frac {c_\rho }{d_\rho }\right )^P,\] using \(|V|-|E|+P=2-2g\). Sum over \(\rho \). For \(f=1\), character orthogonality makes the trivial coefficient one and all others zero.
The exceptional CW description of a sphere with one vertex, no edges and one face attached by a constant map lies outside the nonempty polygon convention. Its partition sum is directly \(f(1)\). The same expression still holds, since \(g=0\), \(P=1\) and \(f(1)=\sum _\rho d_\rho c_\rho \).
For \(G=\{1,-1\}\) and \(f(h)=e^{-\beta (1-h)}\), the two coefficients are \(c_+=e^{-\beta }\cosh \beta \) and \(c_-=e^{-\beta }\sinh \beta \). On the torus the normalized sum is \(c_+^P+c_-^P\). Multiplication by \(2^{|E|}\) recovers the exact square-torus partition function, since \(|E|=2P\). For a disk of \(A\) faces, insertion of its boundary Wilson sign multiplies the face weight by the sign on each interior face. This swaps \(c_+\) and \(c_-\) there. The same edge contraction then gives numerator \[c_-^A c_+^{P-A}+c_+^A c_-^{P-A}.\] Division by the partition sum recovers \((t^A+t^{P-A})/(1+t^P)\), with \(t=\tanh \beta \), under either counting convention.
For character convolution with normalized group integration, see equation (9) in [migdal1975recursion, p. 414]. Witten's Section 2.3 uses normalized Haar measure and character contractions in equations (2.44), (2.48), (2.50)–(2.51) [witten1991quantum, pp. 163–166]. His continuum construction uses heat-kernel face weights with area-dependent Casimir factors. The proof here is for a finite group and an arbitrary fixed central face weight. It does not assert subdivision invariance for the Wilson weight or transfer continuum conclusions to these finite models.
Example. Quaternion spinor gauge fields [fdip-006X]AGENTDRAFTED
- November 1, 2026
Example. Quaternion spinor gauge fields [fdip-006X]AGENTDRAFTED
- November 1, 2026
Take \(G=Q_8=\{\pm 1,\pm i,\pm j,\pm k\}\) in the unit quaternions and its defining complex spinor representation \(\sigma :Q_8\to SU(2)\). Its character is \(\chi _\sigma (h)=2\operatorname {Re}h\). The 4 linear characters factor through \(Q_8/\{\pm 1\}\cong C_2\times C_2\). The spinor has character norm \((2^2+(-2)^2)/8=1\), so is irreducible. These 5 inequivalent irreducibles are complete because \(4\cdot 1^2+2^2=8\). This is the quaternion representation already used in the group-algebra examples.
For the spinor Wilson weight, put \(q=e^{-\beta }\). Then \[f_\beta (1)=1,\qquad f_\beta (-1)=q^2,\qquad f_\beta (\pm i)=f_\beta (\pm j)=f_\beta (\pm k)=q.\] Its irreducible character coefficients are \[\begin {aligned} a&=\frac {1+q^2+6q}{8} &&\text {(trivial)},\\ b&=\frac {(1-q)^2}{8} &&\text {(each other linear character)},\\ c&=\frac {1-q^2}{4} &&\text {(spinor)}. \end {aligned}\] For a nontrivial linear character, the sum over the 6 noncentral units is \(-2\); for the spinor it is zero, while the central values are \(2,-2\). Substitution into the character inner product proves all three formulas. The surface theorem gives \[Z_\Sigma (f_\beta )=a^P+3b^P+ 2^{2-2g}\left (\frac c2\right )^P.\] At \(\beta =0\), only \(a=1\) remains. At the identity, \(a+3b+2c=1\), checking the coefficient normalization.
A one-face torus has one vertex and two loop edges \(x,y\). The square below identifies equally labelled sides in their arrow directions and all 4 corners. A positive boundary traversal is \(x,y,x^{-1},y^{-1}\). Writing \(A=U_x\) and \(B=U_y\), its holonomy is \(H=B^{-1}A^{-1}BA\).
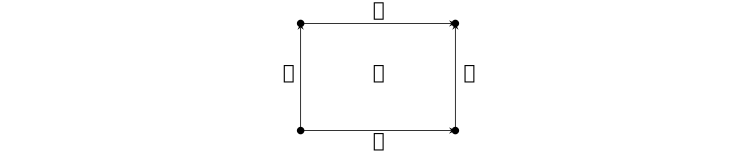
The normalized Wilson loop is \(W_\sigma =\operatorname {Re}H\). Of the \(64\) ordered pairs \((A,B)\), exactly \(40\) commute: the two central elements have centralizer size 8 and the 6 others size 4. Their commutator is \(1\); the other \(24\) commutators are \(-1\). Hence the direct finite sum gives \[Z_{\mathbb T^2}(f_\beta )=\frac {5+3q^2}{8},\qquad \langle W_\sigma \rangle =\frac {5-3q^2}{5+3q^2}.\] The partition formula also follows from \(a+3b+c/2\). This single plaquette is the whole torus, not a disk bounded by a simple contractible loop of the earlier square-torus theorem. Its boundary word can have a nontrivial holonomy because the connection is not constrained to be flat.
Example. Binary tetrahedral spinor gauge fields [fdip-006Y]AGENTDRAFTED
- November 1, 2026
Example. Binary tetrahedral spinor gauge fields [fdip-006Y]AGENTDRAFTED
- November 1, 2026
Let \(G=2T\subset SU(2)\) be the 24 Hurwitz units. Use its defining complex spinor representation \(\sigma \), with \(\chi _\sigma (h)=2\operatorname {Re}h\), for both the Wilson action and the normalized Wilson loops of Definition [fdip-006V]. The complete character table has irreducibles \(1,\lambda ,\lambda ^2,\sigma ,\sigma \lambda , \sigma \lambda ^2,\tau \), with degrees \(1,1,1,2,2,2,3\). Their squared degrees sum to \(24\). The nonreal characters are kept separately as complex irreducibles here; no real isotypic multiplicity is substituted into the surface formula.
Put \(r=e^{-\beta /2}\) and \(\omega =(-1+i+j+k)/2\). In the class order of that table, \[\begin {array}{c|rrrrrrr} h&1&-1&i&\omega &-\omega &\omega ^2&-\omega ^2\\\hline |[h]|&1&1&6&4&4&4&4\\ f_\beta (h)&1&r^4&r^2&r^3&r&r^3&r \end {array}\] The resulting character coefficients are \[\begin {aligned} a&=\frac {1+r^4+6r^2+8r+8r^3}{24} &&(1),\\ b&=\frac {(1-r)^4}{24} &&(\lambda ,\lambda ^2),\\ c&=\frac {(1-r^2)(1+r^2+4r)}{12} &&(\sigma ),\\ d&=\frac {(1-r^2)(1-r)^2}{12} &&(\sigma \lambda ,\sigma \lambda ^2),\\ e&=\frac {(1-r^2)^2}{8} &&(\tau ). \end {aligned}\] To verify them, let \(s_j=\zeta ^j+\zeta ^{2j}\), where \(\zeta =e^{2\pi i/3}\). Thus \(s_0=2\) and \(s_1=s_2=-1\). The class-weighted inner products give \[\begin {aligned} c_{\lambda ^j}&=\frac {1+r^4+6r^2+4s_j(r+r^3)}{24},\\ c_{\sigma \lambda ^j}&=\frac {1-r^4+2s_j(r-r^3)}{12},\\ c_\tau &=\frac {3+3r^4-6r^2}{24}. \end {aligned}\] Factoring these expressions gives the displayed coefficients. They are nonnegative for \(\beta \ge 0\), and \(a+2b+2c+4d+3e=1\). At \(\beta =0\), only \(a=1\) remains; as \(\beta \to \infty \), each coefficient tends to its degree divided by \(24\), the character expansion of the identity indicator.
For the closed oriented surface, \[\begin {aligned} Z_\Sigma (f_\beta )={}&a^P+2b^P\\ &+2^{2-2g}\left [\left (\frac c2\right )^P +2\left (\frac d2\right )^P\right ]\\ &+3^{2-2g}\left (\frac e3\right )^P. \end {aligned}\] Unnormalized counting multiplies this by \(24^{|E|}\). These powers use complex irreducible dimensions; the quaternionic nature of the spinor does not change its complex degree two.
On the one-face torus, set \(g=1\), \(P=1\). Substitution gives \[Z_{\mathbb T^2}(f_\beta ) =a+2b+\frac c2+d+\frac e3 =\frac {7+16r^2+r^4}{24}.\] For its face loop, \(W_\sigma =\operatorname {Re}H\) and \(f_\beta (H)=e^{-\beta (1-W_\sigma )}\). Differentiating the finite sum therefore gives \[\langle W_\sigma \rangle =1+\frac {d}{d\beta }\log Z_{\mathbb T^2}(f_\beta ) =\frac {7-r^4}{7+16r^2+r^4}.\] This differs from the quaternion-group answer, despite using the same spinor trace convention. The calculation concerns the specified finite gauge group and plaquette; it does not identify the finite model with an \(SU(2)\) continuum theory.
Gauge actions induced by matter [fdip-006Z]AGENTDRAFTED
- November 1, 2026
Gauge actions induced by matter [fdip-006Z]AGENTDRAFTED
- November 1, 2026
A connection background determines a positive matter precision. Integrating out the matter field makes its determinant a function of that fixed connection. On a regular lattice, a convergent expansion writes this function as a sum over closed walks. The shortest walks enclosing a square produce a plaquette term, while walks winding around short periodic directions explain why the lattice periods matter.
Real and complex fields have different determinant exponents. Keeping those exponents and the reference volume explicit fixes both the induced coupling and the derivative interpreted as a current. The following statements are finite-volume identities and a controlled large-mass expansion. A joint probability law for matter and a varying connection requires an additional choice of gauge measure and action.
Definition. The determinant action of a fixed connection [fdip-0070]AGENTDRAFTED
- November 1, 2026
Definition. The determinant action of a fixed connection [fdip-0070]AGENTDRAFTED
- November 1, 2026
Use a connection background with its fixed invariant fiber metric and mass \(m>0\). Let \(\mathbb K=\mathbb R\) with an orthogonal representation, or \(\mathbb K=\mathbb C\) with a unitary representation. The matter space is \(\mathcal H=F^V\), and \(N=\dim _{\mathbb K}\mathcal H\) includes the fiber dimension. Write \(d\operatorname {vol}\) for the induced real volume on this space, of real dimension \(N\) or \(2N\), respectively. Set \[\begin {array}{c|cc} \mathbb K&\kappa &d\nu \\\hline \mathbb R&1/2&(2\pi )^{-N/2}d\operatorname {vol}\\ \mathbb C&1&\pi ^{-N}d\operatorname {vol} \end {array}\] and define the matter partition function and determinant action by \[\begin {aligned} Z_{\mathrm {mat}}(U) &=\int _{\mathcal H}e^{-\kappa \langle \phi ,Q_U\phi \rangle }\,d\nu (\phi ),\\ W(U)&=-\log Z_{\mathrm {mat}}(U). \end {aligned}\] The connection is fixed in this integral; only \(\phi \) is integrated.
Orthogonal or unitary diagonalization reduces the integral to positive eigenvalues \(\lambda _1,\ldots ,\lambda _N\). Each real coordinate contributes \(\lambda _j^{-1/2}\) by the real Gaussian integral; each complex coordinate contributes \(\lambda _j^{-1}\) by the complex integral. Therefore \[Z_{\mathrm {mat}}(U)=(\det _{\mathbb K}Q_U)^{-\kappa },\qquad W(U)=\kappa \log \det _{\mathbb K}Q_U.\] The determinant is positive even in the complex case, since \(Q_U\) is positive Hermitian. These reference measures make \(Z_{\mathrm {mat}}=1\) when \(Q_U=I\). The normalized matter law has density \(Z_{\mathrm {mat}}(U)^{-1}e^{-\kappa \langle \phi ,Q_U\phi \rangle }\) with respect to \(\nu \), and covariance \(Q_U^{-1}\) over the chosen field. In the complex convention this means \(\mathbb E[\phi \phi ^*]=Q_U^{-1}\).
A gauge transformation acts unitarily on \(\mathcal H\), and gauge covariance gives \(Q_{U^g}=T_gQ_UT_g^{-1}\). Thus \(W(U^g)=W(U)\). Unitary coordinate changes also preserve the declared real volume. The metric, mass, weights and graph remain supplied data; this determinant does not choose them or yet define a probability law on connections.
Theorem. A convergent expansion over closed walks [fdip-0071]AGENTDRAFTED
- November 1, 2026
Theorem. A convergent expansion over closed walks [fdip-0071]AGENTDRAFTED
- November 1, 2026
Let the vertices be \(\Lambda =\prod _{j=1}^d\mathbb Z/L_j\mathbb Z\), with \(L_j\ge 3\). Give each edge \((x,j):x\to x+e_j\) weight one and a unitary or orthogonal transport \(U_{x,j}\) on a fixed fiber. For the determinant action, put \(D=2d+m^2\), where \(m>0\), and let \(H_U\) be the covariant adjacency operator. Then \[Q_U=DI-H_U,\qquad \|H_U\|\le 2d<D,\] and \[W(U)=\kappa N\log D- \kappa \sum _{k\ge 1}\frac {\operatorname {tr}_{\mathbb K}(H_U^k)}{kD^k}.\] The series is absolutely convergent, uniformly over all such unitary connections. For \(K\ge 0\), its remainder after length \(K\) satisfies \[|R_K(U)|\le \frac {\kappa N}{K+1} \frac {(2d/D)^{K+1}}{1-2d/D}.\] Each trace is the sum of fiber holonomy traces over all based oriented closed nearest-neighbor walks of length \(k\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Define the covariant shift \[(T_j\phi )(x)=U_{x-e_j,j}\phi (x-e_j).\] A permutation of sites and the unitary fiber maps preserve the norm, so \(T_j\) is unitary. Expanding the difference energy gives \[H_U=\sum _{j=1}^d(T_j+T_j^*),\qquad Q_U=(2d+m^2)I-H_U.\] Thus \(H_U\) is self-adjoint and the triangle inequality gives \(\|H_U\|\le 2d\). If its eigenvalues are \(h_1,\ldots ,h_N\), then \(|h_i|/D<1\). Apply the scalar Taylor series for \(\log (1-h_i/D)\) to \(\log \det Q_U=N\log D+\sum _i\log (1-h_i/D)\). There are finitely many eigenvalues and \[|\operatorname {tr}(H_U^k)|\le N(2d)^k,\] so the resulting trace series is absolutely convergent. For \(k\ge K+1\), bound \(1/k\le 1/(K+1)\) and sum the geometric tail. This proves the stated uniform remainder.
The matrix block from \(s(e)\) to \(h(e)\) in \(H_U\) is \(U_e\), and the reverse block is \(U_e^*\). Multiplying \(k\) blocks follows an oriented walk; the diagonal blocks are exactly the closed walks. The ordered product agrees with the transport convention, and taking the fiber trace gives the claimed expansion. Reverse walks pair adjoint products, so the total is real even for a complex fiber.
Mathlib's
Real.hasSum_pow_div_log_of_abs_lt_one states, for a real
\(x\) with \(|x|<1\),
\[\sum _{n\ge 0}\frac {x^{n+1}}{n+1}=-\log (1-x).\]
It supplies the scalar series used for each real eigenvalue. Spectral
reduction, the walk interpretation, the lattice norm bound and the
uniform trace remainder are the additional arguments above; the
formal declaration does not state this lattice expansion.
The numerical bound \(2d\) and scalar diagonal \(D\) use this regular lattice and its unit edge weights. For arbitrary weights or degrees one must change the diagonal decomposition and norm estimate; the displayed bound is not asserted unchanged.
Kazakov and Migdal integrate an adjoint matrix field in a different lattice model. Their Section 2, equations (3)–(4), gives a trace-log and loop weights involving \(|\operatorname {tr}U[\Gamma ]|^2\) [kazakov1992induced, p. 2]. This is a comparison with the closed-walk method. The finite real-scalar coefficient below follows from the present proof, not from their large-\(N\) analysis or a continuum identification.
Theorem. The induced scalar plaquette coefficient [fdip-0072]AGENTDRAFTED
- November 1, 2026
Theorem. The induced scalar plaquette coefficient [fdip-0072]AGENTDRAFTED
- November 1, 2026
On a square torus with both periods at least 6, take a real scalar field and \(G=\{1,-1\}\) in its sign representation. Use unit weights, \(m>0\), \(N=|\Lambda |\) and \(D=4+m^2\). For the plaquette holonomies, \[\begin {aligned} W(U)={}&C(D,N)-\frac 1{D^4}\sum _pU_p+R(U),\\ C(D,N)={}&\frac N2\log D-\frac N{D^2}-\frac {7N}{2D^4},\\ |R(U)|\le {}&\frac N{12}\frac {(4/D)^6}{1-4/D}. \end {aligned}\] Thus the fourth-order induced Wilson coefficient is \(\beta _{\mathrm {ind}}=(4+m^2)^{-4}>0\). The remainder is uniformly \(O(D^{-6})\) in the connection at fixed finite volume as \(D\to \infty \).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
A torus walk of length at most 5 lifts to a walk in \(\mathbb Z^2\) whose displacement in each coordinate is a multiple of the corresponding period. Each displacement has absolute value at most 5, so both must be zero. Such a walk has even length. Consequently \[\operatorname {tr}H_U=\operatorname {tr}H_U^3 =\operatorname {tr}H_U^5=0.\] There are 4 two-step returns at each vertex, each traversing one edge and its inverse, so \(\operatorname {tr}H_U^2=4N\).
There are 36 four-step returns at each vertex of \(\mathbb Z^2\). Of them, 12 use one axis: on either axis there are 6 orderings of two positive and two negative steps. The other 24 use both axes: these are the permutations of the 4 distinct directions. Of those, 8 trace elementary squares; the other 16 retrace edges. All 28 retracing walks have holonomy one. Each plaquette has 4 choices of starting vertex and two orientations, which give the same sign \(U_p\). Hence \[\operatorname {tr}H_U^4=28N+8\sum _pU_p.\] Insert these traces into the closed-walk series, with \(\kappa =1/2\), and use its remainder bound with \(K=5\).
The exact matter factor can therefore be written \[e^{-W(U)}=e^{-C(D,N)} \exp \left (\beta _{\mathrm {ind}}\sum _pU_p\right )e^{-R(U)}.\] The displayed plaquette term favors positive holonomy. Higher closed walks remain in \(R\); the complete determinant is not replaced by a pure plaquette action. Winding walks of length 6 are permitted by the hypothesis and belong to the remainder. On an odd period such as 7, odd winding walks also occur at higher orders; the proof only asserts vanishing through length 5.
Example. Short periods add winding terms [fdip-0073]AGENTDRAFTED
- November 1, 2026
Example. Short periods add winding terms [fdip-0073]AGENTDRAFTED
- November 1, 2026
Start with all links equal to one on an \(L\times L\) square torus, then change one horizontal link to minus one. Keep the real scalar convention, \(D=4+m^2\), and write \(\Delta W=W(U_{\mathrm {flip}})-W(1)\). Two adjacent plaquettes change sign, so \(\Delta \sum _pU_p=-4\). For \(L\ge 6\), the induced plaquette theorem gives \[\Delta W=\frac 4{D^4}+O(D^{-6}),\qquad \frac {\Delta W}{4/D^4}\longrightarrow 1.\] The constants in the error bound may depend on the fixed volume.
For \(L=4\), there are also straight four-step walks winding around a periodic row or column. The changed edge lies in one horizontal winding cycle. It has 4 starting vertices and two orientations, so 8 based walks change holonomy from one to minus one. Their contribution to \(\Delta \operatorname {tr}H^4\) is \(-16\), in addition to the plaquettes' \(8(-4)=-32\). There are no odd closed walks because this torus is bipartite. The same convergent series therefore gives \[\Delta W=\frac 6{D^4}+O(D^{-6}),\qquad \frac {\Delta W}{4/D^4}\longrightarrow \frac 32.\] The extra leading term is winding holonomy, not a different local plaquette coefficient.
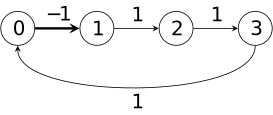
The diagram shows one horizontal row of the \(4\times 4\) torus; vertical edges are omitted. The curved edge is the periodic join. The four-step winding product is minus one, independently of the two neighboring plaquette products.
For \(L=5\), length-4 winding is absent, but each periodic row or column has straight winding walks of length 5. The changed row has 10 such based oriented walks, so \(\Delta \operatorname {tr}H^5=-20\). No other five-step return can wind: displacement 5 requires all 5 steps along that axis. The plaquette change remains \(\Delta \operatorname {tr}H^4=-32\). Consequently \[\Delta W=\frac 4{D^4}+\frac 2{D^5}+O(D^{-6}).\] Thus a period-5 hypothesis would leave an order \(D^{-5}\) term outside the claimed order \(D^{-6}\) remainder. This is why the preceding theorem requires both periods to be at least 6.
Proposition. A link current is an action derivative [fdip-0074]AGENTDRAFTED
- November 1, 2026
Proposition. A link current is an action derivative [fdip-0074]AGENTDRAFTED
- November 1, 2026
Use a complex scalar field on the unit-weight lattice of Theorem [fdip-0071], with \(G=U(1)\), \(U_e=e^{iA_e}\) and \(m>0\). Fix an oriented edge \(e:s\to h\), and let its angle \(A_e\) vary while all other angles are fixed. For the complex matter law, write \[S_U(\phi )=\phi ^*Q_U\phi ,\qquad C_U=Q_U^{-1}.\] Define the sign of the link current by \[J_e(\phi ,U)=\frac {\partial S_U(\phi )}{\partial A_e} =2\operatorname {Im}(\overline {\phi _h}U_e\phi _s).\] Then \[\begin {aligned} \frac {\partial W}{\partial A_e} &=\operatorname {tr}_{\mathbb C} \left (C_U\frac {\partial Q_U}{\partial A_e}\right )\\ &=\mathbb E_U[J_e] =2\operatorname {Im}\bigl (U_e(C_U)_{s,h}\bigr ). \end {aligned}\] All expectations here condition on the fixed connection \(U\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The only angle-dependent edge energy is \[|\phi _h-e^{iA_e}\phi _s|^2 =|\phi _h|^2+|\phi _s|^2 -2\operatorname {Re}(\overline {\phi _h}e^{iA_e}\phi _s).\] Its derivative is the displayed positive twice-imaginary-part expression, fixing the current sign. The matrix derivative has entries \(-iU_e\) in position \((h,s)\) and \(i\overline {U_e}\) in position \((s,h)\), and zero elsewhere. Since \(C_U\) is Hermitian, its trace pairing with that derivative is \(2\operatorname {Im}(U_e(C_U)_{s,h})\).
The determinant derivative used in the edge-variance identity applies equally to complex invertible matrices. Along this real parameter, \(Q_U\) stays positive Hermitian, so its determinant is positive and \[\frac {\partial }{\partial A_e}\log \det _{\mathbb C}Q_U =\operatorname {tr}_{\mathbb C} \left (Q_U^{-1}\frac {\partial Q_U}{\partial A_e}\right ).\] Finally, the complex Gaussian covariance gives \(\mathbb E_U[\overline {\phi _h}\phi _s]=(C_U)_{s,h}\). Substitution into the explicit current proves the expectation identity.
TauCeti's Matrix.fderiv_det_apply supplies
\(D\det (Q)[B]=\det (Q)\operatorname {tr}(Q^{-1}B)\) over a complete
nontrivially normed field when \(\det Q\) is a unit. Complex positive
definiteness supplies invertibility here. The logarithm, angle direction,
current sign and Gaussian expectation are the additional steps above;
the formal declaration does not state this current law.
For a differentiable real orthogonal family, the corresponding convention uses \(S=\frac 12\langle \phi ,Q\phi \rangle \), \(J=\partial S\) and \(W=\frac 12\log \det _{\mathbb R}Q\). Both sides then carry the same factor \(1/2\). In the complex convention used here, neither the action nor the log determinant has that factor.
A dynamical connection and its matter law [fdip-0075]AGENTDRAFTED
- November 2, 2026
A dynamical connection and its matter law [fdip-0075]AGENTDRAFTED
- November 2, 2026
The determinant action is a function of a fixed connection. A measure on connections turns that function into part of a joint law: one may first draw a connection and then draw a Gaussian matter field in it. Integrating over the matter changes the connection's probability, while conditioning on a connection recovers the background Gaussian law.
The matter determinant is at least its value on the identity connection, with equality exactly when every closed walk acts as the identity. A small square torus makes the joint law explicit. Its gauge orbits reduce the calculation to a finite sum of positive determinant weights. At zero bare gauge coupling, scalar matter already changes the plaquette expectation from zero to a strictly positive number. This finite comparison does not determine large-loop screening or an infinite-volume area law.
Definition. The joint gauge and real-matter measure [fdip-0076]AGENTDRAFTED
- November 1, 2026
Definition. The joint gauge and real-matter measure [fdip-0076]AGENTDRAFTED
- November 1, 2026
Fix the graph, positive edge weights and invariant fiber metric of a connection background. When using a Wilson action, also supply square faces and their attaching walks. Let \(G\) be a finite group, or a compact Hausdorff group supplied with a normalized bi-invariant Borel probability measure \(\mu _G\). In the finite case use uniform probability measure. Let \(\rho :G\to O(F)\) be a continuous orthogonal representation on a finite-dimensional real inner-product space; continuity is automatic for a finite group. The compact-group measure is assumed as part of the data here.
Put \(\mathcal H=F^V\), \(N=\dim _{\mathbb R}\mathcal H\) and \(d\mu (U)=\prod _{e\in E}d\mu _G(U_e)\). Choose \(m>0\) and write \(Q_U=L_U+m^2I\). Use a continuous real gauge-invariant action \(S_W(U)\), such as the Wilson action with its declared representation and coupling. With ordinary Lebesgue volume \(d\operatorname {vol}(\phi )\) in the fixed metric, define \[\begin {aligned} \mathfrak Z &=\int _{G^E}\int _{\mathcal H} e^{-S_W(U)-\frac 12\langle \phi ,Q_U\phi \rangle } \,d\operatorname {vol}(\phi )\,d\mu (U),\\ d\mathbb P(U,\phi ) &=\mathfrak Z^{-1} e^{-S_W(U)-\frac 12\langle \phi ,Q_U\phi \rangle } \,d\mu (U)\,d\operatorname {vol}(\phi ). \end {aligned}\] This is a law on both the connection and the real matter field.
The normalization is finite and positive. Indeed, \(Q_U\ge m^2I\), and the continuous action has a finite lower bound on compact \(G^E\). Thus the integrand is bounded by a constant times \(e^{-m^2\|\phi \|^2/2}\), which is integrable. It is everywhere positive. A gauge transformation preserves the edge measure by left and right invariance, the matter volume by orthogonality, and the quadratic form by gauge covariance. Hence the joint law is gauge invariant.
The edge measure differs from the unnormalized counting convention in Definition [fdip-006O]: for finite \(G\), replacing \(\mu \) by counting measure multiplies \(\mathfrak Z\) by \(|G|^{|E|}\) and leaves normalized expectations unchanged. The matter volume is also explicit: it has not been divided by \((2\pi )^{N/2}\).
Theorem. Integrating and conditioning the matter field [fdip-0077]AGENTDRAFTED
- November 1, 2026
Theorem. Integrating and conditioning the matter field [fdip-0077]AGENTDRAFTED
- November 1, 2026
For the joint law, let \(W(U)=\frac 12\log \det _{\mathbb R}Q_U\) and set \[Z_U=\int _{G^E}e^{-S_W(U)-W(U)}\,d\mu (U).\] Then \[\mathfrak Z=(2\pi )^{N/2}Z_U,\qquad d\mathbb P_U(U)=Z_U^{-1}e^{-S_W(U)-W(U)}\,d\mu (U).\] A conditional matter kernel is \[K_U(d\phi )=(2\pi )^{-N/2}(\det Q_U)^{1/2} e^{-\frac 12\langle \phi ,Q_U\phi \rangle } \,d\operatorname {vol}(\phi ),\] so, conditionally on \(U\), the field has law \(N(0,Q_U^{-1})\). In particular the induced action adds to the bare gauge action exactly, with no large-mass approximation.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The real Gaussian integral, converted from its normalized reference volume to ordinary volume, gives \[\int _{\mathcal H}e^{-\frac 12\langle \phi ,Q_U\phi \rangle } \,d\operatorname {vol}(\phi ) =(2\pi )^{N/2}e^{-W(U)}.\] Tonelli's theorem applies to the nonnegative joint density. Integrating first over \(\phi \) proves the normalization and marginal formulas. Dividing the fixed-\(U\) matter density by this Gaussian integral yields \(K_U\). Multiplying the two displayed densities recovers the joint density, proving the disintegration identity \[\mathbb P(dU,d\phi )=\mathbb P_U(dU)K_U(d\phi ).\] This explicitly chosen kernel supplies a conditional version at every connection.
Mathlib's MeasureTheory.lintegral_prod states Tonelli's
identity for an almost-everywhere measurable nonnegative extended-real
function, with an s-finite inner measure. The gauge probability and
finite-dimensional Lebesgue measure satisfy these measure conditions;
the density here is measurable. This is partial support for the
product-integration step, not for the Gaussian evaluation or the
marginal and conditional formulas derived above.
The selected Gaussian marginal and conditional propagator formulas therefore apply separately at each fixed \(U\). For example, in orthonormal retained and eliminated coordinates, write \[Q_U=\begin {pmatrix}A_U&B_U\\B_U^T&C_U\end {pmatrix},\qquad C_U>0.\] Then the retained precision at that connection is \(A_U-B_UC_U^{-1}B_U^T\), and \[\phi _{\mathrm {elim}}\mid (\phi _{\mathrm {ret}}=x,U) \sim N(-C_U^{-1}B_U^Tx,C_U^{-1}).\] These statements keep the connection in the conditioning data.
After averaging over \(U\), the matter law is generally a mixture of Gaussian laws, rather than one Gaussian law. Its covariance is \[\mathbb E_{\mathbb P_U}[Q_U^{-1}],\] by the conditional covariance identity and the zero conditional mean. Observing retained matter coordinates also reweights the distribution of \(U\) by their conditional likelihood. One cannot obtain the joint conditional law by keeping the original connection probabilities fixed and applying a single Gaussian formula.
Theorem. The matter determinant is smallest on the identity orbit [fdip-00A6]AGENTDRAFTED
- November 2, 2026
Theorem. The matter determinant is smallest on the identity orbit [fdip-00A6]AGENTDRAFTED
- November 2, 2026
The massive precision \(Q_U\) depends on the connection. Gauge covariance makes its determinant constant on orbits. The comparison below identifies the minimum. It is the value on the identity connection, attained exactly when every closed walk acts as the identity on the fiber.
Let \(F\) have dimension \(n\) over its scalar field, and let \(Q_1\) be the scalar massive precision of the same finite graph, the same positive edge weights, and the same mass \(m>0\). For every connection, \(\det Q_U\ge (\det Q_1)^n\). Equality holds if and only if every closed walk acts as the identity on \(F\). Every connection in the identity orbit has that property. So does every connection whose holonomy acts through the kernel of \(\rho \).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Write \(D\) for the positive diagonal operator on scalar functions with \(D_v=m^2+\sum _{e\ni v}w_e\), and write \(D_H\) for \(D\) acting separately on each fiber. The quadratic form in the connection background expands as \(\langle f,Q_Uf\rangle =\sum _v D_v\|f_v\|^2-\sum _e 2w_e\operatorname {Re}\langle f(h(e)),U_ef(s(e))\rangle \). The associated self-adjoint operator is \(Q_U=D_H-H_U\), where the only nonzero blocks of \(H_U\) are \(w_eU_e\) and \(w_eU_e^*\). Let \(K_U=D_H^{-1/2}H_UD_H^{-1/2}\). Then \(Q_U=D_H^{1/2}(I-K_U)D_H^{1/2}\), so \(\det Q_U=(\det D)^n\det (I-K_U)\). The identity connection has \(Q_I=Q_1\otimes I_F\), hence \((\det Q_1)^n=\det Q_I\). It is enough to compare \(I-K_U\) with \(I-K_I\).
The scalar adjacency \(A\) has the same off-diagonal weights. Its normalized operator \(K_1=D^{-1/2}AD^{-1/2}\) is self-adjoint, and \(K_I=K_1\otimes I_F\). The similar operator \(D^{-1}A\) has row sums \(\bigl (\sum _{e\ni v}w_e\bigr )/D_v<1\), because \(m>0\). The maximum absolute row sum is strictly less than \(1\), so the spectral radius of \(D^{-1}A\) is strictly less than \(1\). Since \(K_1=D^{1/2}(D^{-1}A)D^{-1/2}\), the operator \(K_1\) has the same spectral radius. Self-adjointness gives \(\|K_1\|=\rho (K_1)<1\).
The same comparison bounds the connection. For a section \(f\), set \(y_v=\|f_v\|\). Each fiber of \(H_U\) has operator norm \(w_e\), so \(\|(H_Uf)_v\|\le (Ay)_v\). Conjugating by \(D^{1/2}\) yields \(\|(K_Uf)_v\|\le (K_1y)_v\). Therefore \(\|K_Uf\|\le \|K_1y\|\le \|K_1\|\|f\|\), and \(\|K_U\|<1\). The eigenvalues of the self-adjoint operator \(K_U\) are real and lie in the open interval \((-1,1)\).
For every such eigenvalue, \(\log (1-\lambda )=-\sum _{k\ge 1}\lambda ^k/k\). Summing over eigenvalues gives \(\log \det (I-K_U)=-\sum _{k\ge 1}\frac 1k\operatorname {tr}(K_U^k)\). Expanding the trace in walks, a closed walk \(\gamma \) of length \(k\) contributes its positive weight \(w(\gamma )=\prod _{e\in \gamma }\frac {w_e}{\sqrt {D_{s(e)}D_{h(e)}}}\) times the trace of its holonomy. The holonomy is the ordered product of the fiber maps, with the first edge on the right, because parallel transport along \(e\) sends \(f(s(e))\) to \(U_ef(s(e))\). A unitary or orthogonal map has eigenvalues on the circle, so the real part of its trace is at most \(n\), with equality exactly when the map is the identity. The trace \(\operatorname {tr}(K_U^k)\) is real and equals the sum of those real parts against the walk weights. Hence \(\operatorname {tr}(K_U^k)\le \operatorname {tr}(K_I^k)=n\operatorname {tr}(K_1^k)\). Since each trace is at most the corresponding identity trace, \(\log \det (I-K_U)\ge \log \det (I-K_I)\). The logarithm is increasing, and \(\det (I-K_U)\ge \det (I-K_I)\). The powers of \(\det D\) cancel in the comparison. This is the asserted lower bound.
Equality of the determinants forces equality of the two series. For every \(k\ge 1\), \[\operatorname {tr}(K_U^k)=\operatorname {tr}(K_I^k).\] Their difference is the sum, over closed walks, of the positive weight times \(n-\operatorname {Re}\operatorname {tr}\operatorname {Hol}(\gamma )\). Each summand is nonnegative, so each vanishes. Every closed walk therefore acts as the identity on \(F\). Conversely, that condition makes every walk contribution agree with the identity connection, and the determinants agree.
These connections are exactly the identity orbit in the represented gauge group. Choose a root in each connected component and propagate \(\rho (U)\) along any walk from that root. The product is independent of the walk because every closed walk acts as the identity. The resulting vertex operators \(g_v\) satisfy \(U_e=g_{h(e)}g_{s(e)}^{-1}\). In the other direction, a gauge transform of the identity has determinant \(\det Q_I\) by the covariance already cited. A holonomy in the kernel of \(\rho \) is invisible to \(Q_U\): equality sees the action on \(F\), not a finer group element.
When \(F\) is real, the induced action \(W(U)=\frac 12\log \det Q_U\) of the joint law is therefore smallest exactly on this orbit. When \(F\) is complex, the same bound says that \((\det Q_U)^{-1}\) is largest there. The massless operator is outside the argument: its identity connection can be singular, and a nontrivial represented holonomy can leave a parallel section, so a zero determinant does not characterize the identity orbit.
On the three-by-three torus with unit weights and mass squared equal to \(1\), the all-positive connection lies on the identity orbit and attains the bound. The torus sum records that determinant.
Example. An exact matter-weighted sum on the three-by-three torus [fdip-0078]AGENTDRAFTED
- November 2, 2026
Example. An exact matter-weighted sum on the three-by-three torus [fdip-0078]AGENTDRAFTED
- November 2, 2026
On a connected graph, take \(G=\{1,-1\}\) acting by multiplication on the real line. Two gauges induce the same action precisely when their ratio is constant, so each orbit contains \(2^{|V|-1}\) connections. A spanning tree meets every vertex and contains no cycle. Requiring its edges to be positive selects one connection from each orbit. With \(b_1=|E|-|V|+1\) and with zero bare coupling, gauge invariance of the determinant converts the marginal into \[Z_U=2^{-b_1}\sum _s(\det Q_s)^{-1/2},\] where \(s\) runs through the sign patterns on the complementary edges.
Take the square torus with both periods three, \(G=\{1,-1\}\), real scalar matter, unit edge weights, \(m^2=1\) and bare coupling \(\beta =0\). Vertices are \((x,y)\) with coordinates in \(\mathbb Z/3\mathbb Z\); use horizontal edges \(a_{x,y}\) and vertical edges \(b_{x,y}\) in the orientations of that definition. There are 9 matter coordinates and 18 links.
Fix a spanning tree by requiring \[a_{0,y}=a_{1,y}=1\quad (y=0,1,2),\qquad b_{0,0}=b_{0,1}=1.\] These 8 edges connect every vertex without a cycle. Parameterize the 10 remaining links by \(s=(s_1,\ldots ,s_{10})\in \{1,-1\}^{10}\): \[\begin {aligned} (a_{2,0},a_{2,1},a_{2,2})&=(s_1,s_2,s_3),\\ (b_{1,0},b_{2,0},b_{1,1},b_{2,1})&=(s_4,s_5,s_6,s_7),\\ (b_{0,2},b_{1,2},b_{2,2})&=(s_8,s_9,s_{10}). \end {aligned}\] Let \(U_e(s)\) denote these assigned signs.
In the vertex order \((0,0),(1,0),(2,0),(0,1),\ldots ,(2,2)\), let \(E_{v,w}\) be a matrix unit and define \[\begin {aligned} H_s&=\sum _{e\in E}U_e(s)(E_{h(e),s(e)}+E_{s(e),h(e)}),\\ d_s&=\det (5I-H_s),\\ P_{x,y}(s)&=a_{x,y}b_{x+1,y}a_{x,y+1}b_{x,y},\\ k(s)&=\#\{(x,y):P_{x,y}(s)=-1\}. \end {aligned}\] The symbol \(s(e)\) in a matrix index is the edge's source vertex; the tuple \(s\) labels the 10 free signs. All subscripts on links are read modulo three. Every \(d_s\) is a positive integer.
For each connection there is a unique gauge transformation with value one at \((0,0)\) that makes the tree links positive: propagate its vertex values along the tree. The only remaining transformations fixing a connection are the two constant signs, since the graph is connected. Hence every gauge orbit has \(2^8\) elements and exactly one displayed representative. Gauge-invariant normalized edge sums therefore reduce to the following exact formulas: \[\begin {aligned} R&=\sum _{s\in \{1,-1\}^{10}}d_s^{-1/2},& Z_U&=2^{-10}R,\\ \langle P_{0,0}\rangle &=\frac {\sum _sP_{0,0}(s)d_s^{-1/2}}{R},& \mathfrak Z&=(2\pi )^{9/2}Z_U. \end {aligned}\] Here \(Z_U\) is the determinant-weighted edge integral, whereas \(\mathfrak Z\) includes ordinary matter volume.
The finite sums contain 1024 terms. They can be evaluated by forming the displayed integer matrix for each sign tuple and taking its determinant. At the all-positive tuple, the eigenvalues of \(5I-H_s\) are \(1\), 4 copies of \(4\), and 4 copies of \(7\), so \(d_s=4^4\cdot 7^4=614656\). This is the lower bound of the matter-determinant comparison. Grouping by the number of negative plaquettes gives the table. The matter probability in row \(k\) is \(R^{-1}\sum _{s:k(s)=k}d_s^{-1/2}\), and the probability without matter is the orbit count divided by \(1024\).
\[\begin {array}{c|r|c|c} k&\text {orbits}&\text {pure gauge }(\beta =0)&\text {with matter}\\\hline 0&4&0.00390625&0.00404317\\ 2&144&0.14062500&0.14286686\\ 4&504&0.49218750&0.49338270\\ 6&336&0.32812500&0.32522204\\ 8&36&0.03515625&0.03448524 \end {array}\]Translation invariance gives the same expectation at every plaquette. The pure-gauge torus law at \(\beta =0\) instead has \(\langle P_{0,0}\rangle =0\). No large-mass truncation was used in these finite sums.
Proposition. A finite loop comparison does not determine screening [fdip-0079]AGENTDRAFTED
- November 1, 2026
Proposition. A finite loop comparison does not determine screening [fdip-0079]AGENTDRAFTED
- November 1, 2026
On a square torus of periods at least three, use the joint law with \(G=\{1,-1\}\) acting by multiplication on the real field \(\phi \in \mathbb R^V\), unit weights, \(m>0\) and \(\beta =0\). For any simple nonempty closed edge cycle \(C\), its Wilson product \(W_C(U)=\prod _{e\in C}U_e\) has \[\langle W_C\rangle _{\mathrm {matter}}>0,\qquad \langle W_C\rangle _{\mathrm {pure}}=0.\] In particular, the strict positivity in the three-by-three example has a direct proof independent of rounding the determinant sums.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Put \(D=4+m^2\). For the real scalar convention, the joint Boltzmann factor at zero bare gauge coupling is \[\exp \left (-\frac D2\sum _v\phi _v^2\right ) \prod _{e\in E}\exp (U_e\phi _{s(e)}\phi _{h(e)}).\] Average the independent edge signs before integrating the matter. Since \[\frac 12\sum _{u=\pm 1}e^{ut}=\cosh t,\qquad \frac 12\sum _{u=\pm 1}u e^{ut}=\sinh t,\] the Wilson expectation is \(I_C/I_{\varnothing }\), where \[\begin {aligned} I_C={}&\int _{\mathbb R^V}e^{-\frac D2\sum _v\phi _v^2} \prod _{e\in C}\sinh (\phi _{s(e)}\phi _{h(e)})\\ &\qquad \qquad \cdot \prod _{e\notin C} \cosh (\phi _{s(e)}\phi _{h(e)})\,d\phi . \end {aligned}\] For \(C=\varnothing \), every edge contributes a hyperbolic cosine. For nonzero vertex coordinates, the sign of the numerator's product of hyperbolic sines is \[\prod _{e\in C}\operatorname {sgn}(\phi _{s(e)}\phi _{h(e)}) =\prod _{v\in C}\operatorname {sgn}(\phi _v)^2=1.\] Each cycle vertex occurs twice. All other factors are strictly positive, so the numerator integrand is positive off coordinate hyperplanes. Its absolute value is bounded by the denominator integrand because \(|\sinh t|\le \cosh t\). Positive mass makes the latter integrable by the joint-law bound. Both integrals are therefore finite and strictly positive. In the pure law, independent uniform edge signs give zero expectation for any nonempty product of distinct edges, proving the comparison.
Integrating matter has changed the connection law, so the exact pure-gauge formula cannot be reused unchanged. On tori with periods at least 6, the closed-walk calculation gives a separate controlled large-mass explanation: matter generates a positive plaquette coefficient and higher loop terms. Its order \(D^{-6}\) remainder is not being applied to the three-by-three example, where short winding cycles occur.
Neither the finite comparison nor the positive plaquette term establishes an asymptotic area law, a perimeter law or string breaking. Such a claim needs a specified family of volumes and loops, a limiting regime and control of the higher terms. Gliozzi and Rago study a different system: a three-dimensional two-element gauge group coupled to Ising matter taking only the values \(\pm 1\), rather than an unbounded Gaussian field. Their Section 3, equation (12), fixes that action; their analysis of Wilson-loop overlap with a broken-string state is model-specific context [gliozzi2004overlap, pp. 2, 5]. It does not supply a screening theorem for the present Gaussian law.
Compact gauge groups and representation data [fdip-007A]AGENTDRAFTED
- November 1, 2026
Compact gauge groups and representation data [fdip-007A]AGENTDRAFTED
- November 1, 2026
Replacing a finite gauge group by a compact group changes edge sums into normalized Haar integrals. Character orthogonality survives, but an infinite character expansion needs a convergence argument before it can be inserted into a surface partition function. The distinction between an \(L^2\) expansion and an absolutely convergent kernel is therefore part of the model.
For the circle group, Wilson and Villain weights give explicit Fourier coefficients. Matching one coefficient does not match the whole law. For matrix groups, a separate smooth-field calculation explains the classical small-spacing normalization of the Wilson action. Neither calculation constructs a quantum continuum limit.
Unit quaternions identify the compact group \(SU(2)\) and its binary polyhedral subgroups. A representation datum then specifies which group acts on which field and whether it also moves the substrate. These choices precede any physical comparison.
Theorem. Normalized Haar measure [fdip-007B]AGENTDRAFTED
- November 1, 2026
Theorem. Normalized Haar measure [fdip-007B]AGENTDRAFTED
- November 1, 2026
Every compact Hausdorff topological group \(G\) has a unique regular Borel probability measure \(\mu _G\) invariant under left translation. This is the normalized Haar theorem, used here as a cited statement; existence and uniqueness are not proved in these notes. The existence and uniqueness-up-to-scale statements are Theorems 4.3 and 4.6 in [gleason2010haar, pp. 6, 11]. Compactness permits normalization to total mass one.
The normalized measure is also invariant under right translation and inversion. Indeed, a right translate of \(\mu _G\) is another left-invariant regular probability measure, hence equals \(\mu _G\) by uniqueness. The pushforward under inversion is then left invariant, because inversion changes left translations into right translations; it too has total mass one and equals \(\mu _G\). These deductions explain why the same measure works with either orientation of an edge.
Every nonempty open set has positive Haar measure. If an open set had measure zero, choose a point in it; its left translates cover \(G\), and compactness gives a finite subcover, contradicting total mass one. Consequently a continuous function that vanishes \(\mu _G\)-almost everywhere vanishes everywhere.
For a finite group this measure is uniform counting. For \(U(1)=\{e^{i\theta }:\theta \in \mathbb R\}\), it is \(d\theta /(2\pi )\) on one period: translation invariance and total mass one identify this measure by uniqueness. Product Haar measure on the edge space \(G^E\) supplies the compact measure assumed in the joint matter law. For \(U(1)\) and \(SU(2)\), all spaces here are compact metrizable, so their Borel products have the usual product measurable structure.
Mathlib constructs Haar measure as
MeasureTheory.Measure.haarMeasure, normalized on a chosen
compact set with nonempty interior; for compact \(G\), choose that
set to be all of \(G\). The separate declaration
MeasureTheory.Measure.isHaarMeasure_eq_of_isProbabilityMeasure
asserts equality of two Haar probability measures on a locally compact
topological group with its Borel measurable structure. It has no
second-countability assumption. These are correspondences for the
construction and normalized uniqueness, respectively; the right and
inversion invariance arguments above are stated separately.
Theorem. Compact character expansions and surface integrals [fdip-007C]AGENTDRAFTED
- November 1, 2026
Theorem. Compact character expansions and surface integrals [fdip-007C]AGENTDRAFTED
- November 1, 2026
Let \(G\) be a compact Lie group with normalized Haar measure. Choose unitary representatives of its complex irreducibles, indexed by \(\widehat G\), with dimensions \(d_\rho \). The Peter–Weyl theorem says that the functions \(\sqrt {d_\rho }\rho (\cdot )_{ij}\) form an orthonormal basis of \(L^2(G)\). Its central subspace has orthonormal basis \(\chi _\rho \). Thus a central \(f\in L^2(G)\) has the expansion \[f=\sum _{\rho \in \widehat G}c_\rho \chi _\rho , \qquad c_\rho =\int _G f(h)\overline {\chi _\rho (h)}\,d\mu _G(h),\] with convergence in \(L^2\). This is a cited statement, namely Woit's Section 5, Theorem 1 and Corollary 1 [woit2012peterweyl, p. 6]. It does not assert pointwise or absolute convergence for an arbitrary \(L^2\) function.
For an inequivalent exhaustive family of finite-dimensional unitary
continuous models, TauCeti's
TauCeti.peterWeylBasis constructs the normalized
matrix-coefficient Hilbert basis, with its inner-product convention
for matrix coefficients. Over \(\mathbb C\), its coefficient
\(\langle \rho (g)e_a,e_b\rangle \) is the conjugate of the matrix
entry \(\rho (g)_{ba}\); conjugation, or reindexing by dual
representations, gives the equivalent entry-coordinate basis.
The separate TauCeti.characterBasis constructs
the actual character basis of the central \(L^2\) subspace.
Compact Hausdorff groups over \(\mathbb C\), hence the compact Lie
groups here, satisfy the stated hypotheses. These correspondences
support the two \(L^2\) basis statements, not the uniform absolute
convergence or surface integral established next.
Suppose now that \(f\) is continuous and central and that \[\sum _{\rho \in \widehat G}|c_\rho |d_\rho <\infty .\] Then its character expansion converges uniformly and absolutely. For the closed oriented polygonal surface, with \(P\) faces and genus \(g\), define the edge integral \[Z_\Sigma (f)=\int _{G^E}\prod _p f(U_p)\,d\mu (U).\] Under the displayed summability condition, \[Z_\Sigma (f)=\sum _{\rho \in \widehat G} d_\rho ^{2-2g}\left (\frac {c_\rho }{d_\rho }\right )^P,\] and this numerical series is absolutely convergent.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Unitarity gives \(|\chi _\rho (h)|\le d_\rho \). The sum of the uniform bounds is finite, so the character series has a continuous uniform limit. Peter–Weyl identifies that limit with \(f\) in \(L^2\); continuity and full support of Haar measure make the equality pointwise. Expanding a product over the finite face set gives a sum whose total absolute value is bounded uniformly by \[\left (\sum _\rho |c_\rho |d_\rho \right )^P.\] This bound is integrable against probability measure, justifying interchange of the full face-label sum and the edge integrals.
Haar averaging gives the same matrix orthogonality as finite averaging: for \(A:V_\tau \to V_\rho \), the integral \(\int _G\rho (h)A\tau (h)^{-1}\,d\mu _G(h)\) is an intertwiner. Schur's lemma and its trace make it zero for inequivalent representatives and \((\operatorname {tr}A/d_\rho )I\) for equal ones. The edge contractions and circular vertex links in the finite surface proof therefore leave one common face label and one free index per vertex. Their contribution is \(c_\rho ^P d_\rho ^{|V|-|E|}\), the displayed formula. Absolute convergence follows as well: the absolute values of these integrated terms are bounded by the integrals of the absolute face terms, whose total has just been bounded. In particular \(f=1\) still gives \(Z_\Sigma (1)=1\).
Definition. Convolution kernels with positive coefficients [fdip-007I]AGENTDRAFTED
- November 1, 2026
Definition. Convolution kernels with positive coefficients [fdip-007I]AGENTDRAFTED
- November 1, 2026
For a finite or compact Lie group \(G\), use the normalized Haar measure, irreducibles and dimensions of the character expansion. For convolution constructions, consider real continuous central kernels \(k\) with the separate hypotheses \[\begin {gathered} k(h)>0,\qquad k(h^{-1})=k(h),\\ k(h)=\sum _{\rho \in \widehat G}d_\rho a_\rho \chi _\rho (h), \qquad a_\rho >0,\qquad \sum _{\rho \in \widehat G}d_\rho ^2a_\rho <\infty . \end {gathered}\] The last condition gives uniform absolute convergence; inversion symmetry and reality impose the corresponding agreement of conjugate coefficients. The convention is \(c_\rho =d_\rho a_\rho \), not \(c_\rho =a_\rho \). These are assumptions on a kernel, not consequences of the Peter–Weyl theorem. In particular, pointwise positivity does not imply the coefficient condition, as the circle counterexample shows.
Example. A positive weight with a negative coefficient [fdip-007J]AGENTDRAFTED
- November 1, 2026
Example. A positive weight with a negative coefficient [fdip-007J]AGENTDRAFTED
- November 1, 2026
On \(U(1)\), take \(0<\epsilon <1\) and \[k(e^{i\theta })=1-\epsilon \cos \theta =1-\frac \epsilon 2 e^{i\theta }-\frac \epsilon 2 e^{-i\theta }.\] This is a real continuous central function, unchanged by inversion, and \(k\ge 1-\epsilon >0\). Its character coefficients at \(n=\pm 1\) are nevertheless \(-\epsilon /2\). Thus the pointwise and Fourier positivity assumptions in the kernel definition are distinct.
Proposition. Wilson and Villain coefficients on the circle [fdip-007D]AGENTDRAFTED
- November 1, 2026
Proposition. Wilson and Villain coefficients on the circle [fdip-007D]AGENTDRAFTED
- November 1, 2026
For \(G=U(1)\), use characters \(\chi _n(e^{i\theta })=e^{in\theta }\) with \(n\in \mathbb Z\) and normalized Haar measure \(d\theta /(2\pi )\). For \(\beta >0\), the Wilson weight \(w_\beta (\theta )=e^{\beta \cos \theta }\) has coefficients \[I_n(\beta )=\sum _{j=0}^\infty \frac {(\beta /2)^{2j+|n|}}{j!(j+|n|)!}>0, \qquad \sum _{n\in \mathbb Z}I_n(\beta )=e^\beta .\] Thus its character series is uniformly absolutely convergent. The Wilson action convention includes the additional constant factor \(e^{-\beta }\); this multiplies all coefficients but cancels from the normalized one-plaquette probability.
TauCeti's
Real.integral_exp_mul_cos_mul_cexp
proves the Wilson circle integral with exponent \(+in\theta \) and
unnormalized measure on \([-\pi ,\pi ]\). Replacing \(n\) by \(-n\)
and dividing by \(2\pi \) gives the coefficient convention here;
its Bessel value has the displayed power series. This correspondence
supports the Wilson coefficient identity, not the Villain formula
or the comparison of the two weights.
For \(\beta _V>0\), the Villain weight is the periodic Gaussian \[v_{\beta _V}(\theta )=\sum _{\ell \in \mathbb Z} \exp \left [-\frac {\beta _V}{2}(\theta -2\pi \ell )^2\right ].\] Its character coefficient is \[c_n^V=(2\pi \beta _V)^{-1/2} e^{-n^2/(2\beta _V)}.\] The coefficient series is again uniformly absolutely convergent and all coefficients are strictly positive. Dividing each weight by its zeroth coefficient normalizes its integral to one, giving \[\widehat c_n^W=\frac {I_n(\beta )}{I_0(\beta )},\qquad \widehat c_n^V=e^{-n^2/(2\beta _V)}.\] These normalized coefficients differ from the unnormalized \(c_\rho \) in the surface formula.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Put \(z=e^{i\theta }\). Multiply the two absolutely convergent series for \(\exp (\beta z/2)\) and \(\exp (\beta z^{-1}/2)\). The coefficient of \(z^n\) is the displayed \(I_n\); the total of all absolute coefficients is the product \(e^{\beta /2}e^{\beta /2}\). Every \(I_n\) is positive for \(\beta >0\).
For the periodic Gaussian, uniform Gaussian tail bounds on a period justify continuity and integration term by term. Unfolding its coefficient integral gives \[c_n^V=\frac 1{2\pi }\int _{\mathbb R} e^{-\beta _V x^2/2}e^{-inx}\,dx.\] For real \(t\), let \(J(t)\) be the integral without \(1/(2\pi )\) and with \(n\) replaced by \(t\). Gaussian domination permits differentiation under the integral. Integration by parts, with vanishing boundary terms, gives \(J'(t)=-(t/\beta _V)J(t)\). Since \(J(0)=\sqrt {2\pi /\beta _V}\), this proves the coefficient formula. The Gaussian coefficient bound is summable over \(n\). Its uniformly convergent Fourier series has the same coefficients as the continuous periodic Gaussian, so completeness of the character basis and continuity identify the two functions. Finally, the integral of a weight is its zeroth coefficient, which proves the normalization.
Both positive-parameter weights satisfy the positive-character kernel hypotheses: they are real, strictly positive, invariant under inversion, and have positive summable coefficients. For \(U(1)\) every irreducible dimension is one. This checks the kernel assumptions without asserting any transfer-operator or continuum conclusion.
Theorem. The matched Wilson and Villain laws differ [fdip-007E]AGENTDRAFTED
- November 2, 2026
Theorem. The matched Wilson and Villain laws differ [fdip-007E]AGENTDRAFTED
- November 2, 2026
A single \(U(1)\) plaquette has the normalized Wilson or Villain weight. Matching their fundamental Fourier coefficients determines a Villain coupling for every Wilson coupling. The two probability laws still differ.
For \(\beta >0\), write \(r(\beta )=I_1(\beta )/I_0(\beta )\) and \(\beta _V(\beta )=-\frac {1}{2\log r(\beta )}\). Then \(0<r(\beta )<1\), the matched Villain coefficient is \(r(\beta )^{n^2}\), and \[\frac {\widehat c_n^W}{\widehat c_n^V}\to \infty \] as \(|n|\to \infty \). In particular the two normalized weights are distinct, so they define distinct probability laws on the circle. The second Wilson coefficient is \(1-\frac {2r(\beta )}{\beta }\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The series for \(I_1\) has positive terms, so \(r>0\). With normalized Haar measure, \[\int (1-\cos \theta )\,e^{\beta \cos \theta }\,\frac {d\theta }{2\pi } =I_0(\beta )-I_1(\beta ).\] The integrand is nonnegative and not identically zero, and the exponential is positive, so the integral is positive. Thus \(r<1\), the logarithm is negative, and \(\beta _V\) is positive. The Villain normalization in the coefficient note gives \(\widehat c_n^V=\exp (-n^2/(2\beta _V))\). Substituting the displayed \(\beta _V\) produces \(1/(2\beta _V)=-\log r\), hence \(\widehat c_n^V=r^{n^2}\).
The \(j=0\) term of the series for \(I_n(\beta )\), with \(n\ge 0\), is \((\beta/2)^n/n!\). Every term is positive, so \(I_n(\beta )\ge (\beta/2)^n/n!\). Therefore \(\widehat c_n^W=I_n(\beta )/I_0(\beta )\) satisfies \[\frac {\widehat c_n^W}{r^{n^2}} \ge \frac {(\beta/2)^n}{n!\,I_0(\beta )\,r^{n^2}}.\] For \(n\ge 1\), one has \(n!\le n^n\), so the logarithm of the right-hand side is at least \(n\log (\beta/2)-n\log n-\log I_0(\beta )-n^2\log r\). The last summand tends to \(+\infty \) because \(\log r<0\), and it dominates the remaining terms. The lower bound tends to infinity, and so does the ratio, as \(n\to +\infty \). The series in the coefficient note depends on \(|n|\), so \(I_n(\beta )=I_{-n}(\beta )\). The matched Villain coefficient \(r^{n^2}\) is likewise unchanged when \(n\) is replaced by \(-n\). The ratio at \(-n\) equals the ratio at \(n\), and the same limit holds as \(|n|\to \infty \).
The coefficient note identifies each normalized continuous weight with its Fourier series. Some coefficient of large order differs, so the weights differ as functions and as probability laws.
The same series gives the second coefficient. The identity \(\frac {2}{\beta }(\beta/2)^{2j+1}=(\beta/2)^{2j}\) rewrites \[\frac {2}{\beta }I_1(\beta ) =\sum _{j\ge 0}\frac {(\beta/2)^{2j}}{j!\,(j+1)!}.\] Subtracting from \(I_0\) cancels the \(j=0\) term. For \(j\ge 1\) the difference of the summands is \(\frac {(\beta/2)^{2j}\,j}{j!\,(j+1)!} =\frac {(\beta/2)^{2j}}{(j-1)!(j+1)!}\), which is the \(j-1\) term of \(I_2\). Hence \(I_0-I_2=\frac {2}{\beta }I_1\), and \(\widehat c_2^W=1-\frac {2r(\beta )}{\beta }\). At \(\beta =2\) this coefficient is \(1-r(2)\), while the matched Villain coefficient is \(r(2)^4\).
The comparison is a one-plaquette identity. It does not assert a many-plaquette continuum limit.
Proposition. The classical small-spacing Wilson action [fdip-007F]AGENTDRAFTED
- November 1, 2026
Proposition. The classical small-spacing Wilson action [fdip-007F]AGENTDRAFTED
- November 1, 2026
Fix a flat \(d\)-dimensional torus with \(d\ge 2\), a compact Lie group \(G\), and a unitary representation \(\rho :G\to U(r)\), \(r>0\). Choose smooth periodic Hermitian fields \(A_j(x)\) such that \(iA_j(x)\) lies in the image of the derived Lie-algebra representation. All derivative bounds are fixed as the mesh spacing \(a\to 0\); take meshes whose periods fit the torus. Define head-directed midpoint links \[U_j(x)=\exp \left (ia A_j(x+\tfrac a2 e_j)\right ).\] With the rightmost-first transport convention, the \(j\)-then-\(k\) plaquette is \[U_{jk}(x)=U_k(x)^*U_j(x+ae_k)^*U_k(x+ae_j)U_j(x).\] Its curvature convention is \[F_{jk}=\partial _jA_k-\partial _kA_j-i[A_j,A_k].\] The matrices \(F_{jk}\) are Hermitian.
For the Wilson action \[S_W(a)=\beta \sum _x\sum _{j<k} \left (1-\frac {\operatorname {Re}\operatorname {tr}U_{jk}(x)}r\right ),\] one has \[S_W(a)=\frac {\beta a^{4-d}}{2r} \int \sum _{j<k}\operatorname {tr}(F_{jk}(x)^2)\,dx +O(\beta a^{5-d}).\] This is a statement about evaluating a discrete action on a fixed smooth field. The constant in the remainder depends on that field, the fixed torus and the representation.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Taylor-expand the 4 midpoint values at \(x\) and use \(e^{iaA}=I+iaA-\tfrac 12a^2A^2+O(a^3)\). The terms of order \(a\) cancel. The variation of the two transverse links contributes \(ia^2(\partial _jA_k-\partial _kA_j)\); the products of first-order terms contribute \(a^2[A_j,A_k]\). The midpoint derivatives along each link cancel between opposite traversals. Hence, uniformly in \(x\), \[U_{jk}(x)=I+ia^2F_{jk}(x)+O(a^3).\] To obtain the real trace to the needed order, use the exact identity for a unitary \(r\times r\) matrix: \[1-\frac {\operatorname {Re}\operatorname {tr}U}{r} =\frac 1{2r}\operatorname {tr}\bigl ((U-I)^*(U-I)\bigr ).\] Substitution yields \[1-\frac {\operatorname {Re}\operatorname {tr}U_{jk}(x)}r =\frac {a^4}{2r}\operatorname {tr}(F_{jk}(x)^2)+O(a^5).\] There are \(O(a^{-d})\) plaquettes. After multiplication by \(a^d\), the Riemann sum for \(\sum _{j<k}\operatorname {tr}(F_{jk}^2)\) differs from its integral by \(O(a)\). Summing the uniform error and this Riemann-sum error proves the formula.
To fix a component convention, suppose the Hermitian generators in the chosen representation satisfy \[\operatorname {tr}(T_\alpha T_\gamma ) =T(\rho )\delta _{\alpha \gamma },\qquad T(\rho )>0.\] Write \(F_{jk}=\sum _\alpha F_{jk}^\alpha T_\alpha \) and fix \(g>0\). Choosing \[\beta =\frac {r a^{d-4}}{T(\rho )g^2}\] gives the classical limit \[\begin {aligned} S_W(a)&=\frac 1{2g^2}\int \sum _{j<k,\alpha }(F_{jk}^\alpha )^2\,dx+O(a)\\ &=\frac 1{4g^2}\int \sum _{j,k,\alpha }(F_{jk}^\alpha )^2\,dx+O(a). \end {aligned}\] The second sum counts both orders, with \(F_{kj}=-F_{jk}\) and \(F_{jj}=0\). The trace normalization is an explicit assumption; it must not be imposed on directions annihilated by a nonfaithful representation. For the fundamental representation of \(SU(r)\) with \(T(\rho )=1/2\), this is \(\beta =2r a^{d-4}/g^2\). For unit-charge \(U(1)\), \(r=T(\rho )=1\), giving \(\beta =a^{d-4}/g^2\).
The matrices \(A_j\) are those appearing in the link exponential; any coupling absorbed into them must be retained when comparing component conventions. Wingate's equation (6.20) and Exercise 2 [wingate2025lattice, p. 8] give the Wilson-action context and the four-dimensional fundamental normalization. The ordered expansion and error estimate above are derived with the convention stated here. They do not prove convergence of lattice probability measures, renormalization or the existence of a quantum continuum theory.
Proposition. Unit quaternions and binary rotation groups [fdip-007G]AGENTDRAFTED
- November 1, 2026
Proposition. Unit quaternions and binary rotation groups [fdip-007G]AGENTDRAFTED
- November 1, 2026
The unit quaternions are isomorphic to \(SU(2)\) by \[M(a+bi+cj+dk)= \begin {pmatrix}a+bi&c+di\\-c+di&a-bi\end {pmatrix}.\] Conjugation on the imaginary quaternions defines a surjective homomorphism \[\pi :SU(2)\longrightarrow SO(3),\qquad \pi (M(q))(v)=qvq^{-1},\qquad \ker \pi =\{1,-1\}.\] For the proper rotation groups \(R_T,R_O,R_I\) of the regular tetrahedron, octahedron and icosahedron, define \[2T=\pi ^{-1}(R_T),\qquad 2O=\pi ^{-1}(R_O),\qquad 2I=\pi ^{-1}(R_I).\] Their orders are respectively \(24,48,120\). Each quotient by \(\{1,-1\}\) is its indicated rotation group.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The images of \(i,j,k\) satisfy the quaternion multiplication relations, so \(M\) is an injective real-algebra homomorphism. Direct calculation gives \[M(q)^*M(q)=|q|^2I,\qquad \det M(q)=|q|^2.\] Conversely, a special unitary matrix of degree two has the form \[\begin {pmatrix}z&w\\-\overline w&\overline z\end {pmatrix}, \qquad |z|^2+|w|^2=1,\] by orthonormality of its columns and determinant one. Taking real and imaginary parts of \(z,w\) gives a unique unit quaternion. This proves the group identification.
Conjugation preserves imaginary quaternions and their norm, so gives an orthogonal map of \(\mathbb R^3\). Its determinant is one: it depends continuously on the unit quaternion, the sphere \(S^3\) is connected, and at \(q=1\) it equals one. A quaternion commuting with all of \(i,j,k\) is real, so the kernel on unit quaternions is \(\{1,-1\}\). More explicitly, for a unit imaginary quaternion \(n\) and \(q=\cos (\theta /2)+n\sin (\theta /2)\), quaternion multiplication gives \[qvq^{-1}=v\cos \theta +(n\times v)\sin \theta +n(n\cdot v)(1-\cos \theta ).\] This is rotation through \(\theta \) about \(n\). Every element of \(SO(3)\) has an axis: its real orthogonal eigenvalues include one, and its restriction to the perpendicular plane is a planar rotation. The displayed formula therefore proves surjectivity.
The proper rotations of a regular solid act transitively on its vertices. A rotation fixing a vertex must rotate its incident edges cyclically about the center-to-vertex axis; all those cyclic rotations are symmetries. The tetrahedron has 4 vertices with stabilizer order three; the octahedron has 6 with stabilizer order 4; the icosahedron has 12 with stabilizer order 5. Orbit–stabilizer therefore gives \(|R_T|=12\), \(|R_O|=24\), \(|R_I|=60\). Every rotation has exactly two lifts under \(\pi \), giving the stated binary group orders and quotients.
For any of the three rotation groups \(R\), the square records the subgroup and its central double cover. In particular, the Hurwitz-unit model of \(2T\) is this tetrahedral preimage. Its quaternion generators \(i,j,k\) and \((-1+i+j+k)/2\) preserve the 4 imaginary vectors \((1,1,1)\), \((1,-1,-1)\), \((-1,1,-1)\), \((-1,-1,1)\): the first generators change two coordinate signs, and the last cyclically permutes coordinates. Its 24 elements therefore exhaust the preimage. This identifies the group used in the finite spinor gauge example.
TauCeti's
Quaternion.unitaryEquivSpecialUnitaryGroup
formalizes precisely the group equivalence between unit Hamilton
quaternions and \(SU(2)\), using the displayed matrix map. This
correspondence does not assert the \(SO(3)\) quotient or the three
binary subgroup identifications; those have their separate arguments
above. A finite subgroup supplies an available group action, not a
physical interpretation of that action.
Definition. A representation datum for a field [fdip-007H]AGENTDRAFTED
- November 1, 2026
Definition. A representation datum for a field [fdip-007H]AGENTDRAFTED
- November 1, 2026
A representation datum specifies a finite discrete or compact Hausdorff group \(G\), a scalar field \(\mathbb K\in \{\mathbb R,\mathbb C\}\), a finite-dimensional fiber \(F\) over \(\mathbb K\), a continuous representation \(\rho :G\to GL_{\mathbb K}(F)\), and a separately chosen action \(\alpha :G\to \operatorname {Aut}(X)\) on the finite substrate \(X\). The substrate automorphisms preserve the graph, weights and any supplied oriented cell data, with orientation changes interpreted by the established inverse-transport convention. One must also specify a positive invariant real or Hermitian inner product on \(F\). The field itself is a map \(\phi :V\to F\).
An invariant inner product always exists for these groups. From any positive inner product \(h_0\), define \[h(v,w)=\int _G h_0(\rho (g)v,\rho (g)w)\,d\mu _G(g).\] The normalized Haar measure makes this invariant by a change of variable. The integral is finite by compactness, and \(h(v,v)>0\) for \(v\ne 0\), since \(\rho (g)v\ne 0\) for every \(g\). This proves existence of an invariant metric; it does not make that metric a canonical choice. A selected metric remains part of the background data.
The global action associated to the datum is \[(g\cdot \phi )(v)=\rho (g)\phi (\alpha (g)^{-1}v).\] The two actions have different roles. For a purely internal group, \(\alpha \) is trivial: the group acts on values without moving vertices. A local gauge transformation instead assigns an element \(g_v\) independently at each vertex and transforms links by \(U_e\mapsto g_{h(e)}U_eg_{s(e)}^{-1}\). It fixes the substrate; a global substrate action \(\alpha \) cannot simply be applied independently at each vertex.
If a field has an additional spin space \(S\), an internal action on \(S\otimes F\) is \(1_S\otimes \rho (g)\). Clifford operators \(\gamma _j\otimes 1_F\) then commute with that action because they act on different factors. An identification of internal and spin symmetries, or an action moving the substrate, needs extra compatible data; it is not implied by the abstract group name or by an inclusion in \(SU(2)\).
Example. Two fibers for binary tetrahedral symmetry [fdip-007K]AGENTDRAFTED
- November 1, 2026
Example. Two fibers for binary tetrahedral symmetry [fdip-007K]AGENTDRAFTED
- November 1, 2026
Take the binary tetrahedral group and a fixed finite substrate, with trivial substrate action in the representation datum. Its spinor datum uses \(\mathbb K=\mathbb C\), \(F=\mathbb C^2\) with its standard Hermitian metric, and the inclusion \(2T\subset SU(2)\). Its rotation datum uses \(\mathbb K=\mathbb R\), \(F=\mathbb R^3\) with its Euclidean metric, and the representation obtained through \(\pi :SU(2)\to SO(3)\).
The latter kills \(\{1,-1\}\), while the former is faithful. Thus these choices define different fibers and observables even though the abstract group and the substrate are the same. The spinor Wilson calculation uses the former. A choice of \(G\) alone would not select that representation.
Reflection positivity on a finite time lattice [fdip-007L]AGENTDRAFTED
- November 1, 2026
Reflection positivity on a finite time lattice [fdip-007L]AGENTDRAFTED
- November 1, 2026
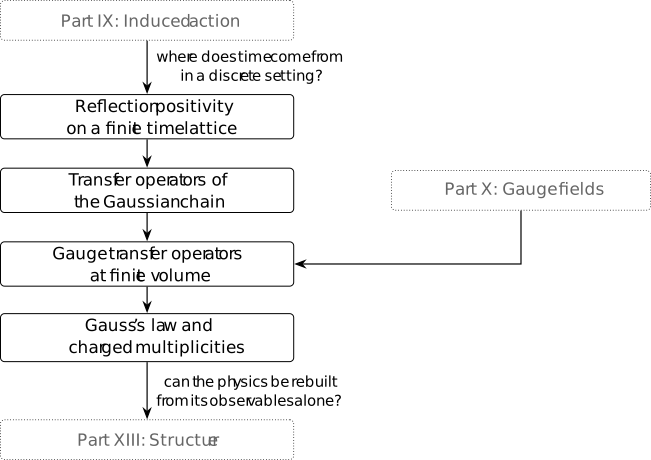
Where could time evolution come from when a law describes all lattice sites at once? Choose one direction to test as Euclidean time. Reflection positivity asks whether observables on one half of the lattice have a positive semidefinite pairing with their reflected partners. Quotienting the vectors of zero length and completing gives a Hilbert space. Reflection positivity is stronger than invariance of the probability law under reflection. The two-site Gaussian makes the sign of a crossing interaction visible.
The scalar result below uses a finite nearest-neighbor torus, reflection-invariant nonnegative weights and positive mass. Its proof first treats a bounded field range, then removes that cutoff. Site reflections retain shared boundary coordinates; link reflections split the sites into disjoint halves. Neither choice makes a time translation an operator on the resulting quotient without further assumptions.
A step of evolution therefore needs more than this positive pairing. The later Gaussian transfer operator uses a nearest-neighbor kernel with positive weight and mass and a specified reference measure; the gauge transfer construction specifies a positive character kernel and gauge projection. Their spectral hypotheses and normalizations permit a Hamiltonian logarithm. These are Euclidean transfer constructions, not an automatic normalized real-time probability evolution.
Definition. Reflections, halves and the positive-time domain [fdip-007M]AGENTDRAFTED
- November 1, 2026
Definition. Reflections, halves and the positive-time domain [fdip-007M]AGENTDRAFTED
- November 1, 2026
Let \(Y\) be a finite spatial torus with coordinate periods at least three, or a point. Put \(X=Y\times \mathbb Z/(2M)\), where \(M\ge 2\); the second coordinate is the chosen time direction. The nearest-neighbor graph joins sites differing by one coordinate step, with each undirected edge counted once. Time indices below are taken modulo \(2M\). Define the site reflection and link reflection by \[\theta _s(y,t)=(y,-t),\qquad \theta _\ell (y,t)=(y,1-t).\] Their positive halves and fixed sets are \[\begin {aligned} X_+^s&=Y\times \{0,\ldots ,M\},& X_0^s&=Y\times \{0,M\},\\ X_+^\ell &=Y\times \{1,\ldots ,M\},& X_0^\ell &=\varnothing . \end {aligned}\] In either case set \(X_-=\theta X_+\). Then \(X_+\cup X_-=X\) and \(X_+\cap X_-=X_0\); sites in \(X_0\) are fixed individually.
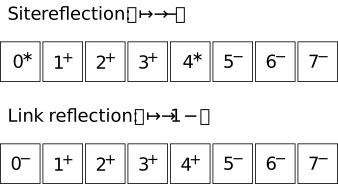
The diagram shows one time circle of length 8. A plus or minus marks an interior site of that half; a star marks a fixed site shared by both halves. Time \(7\) is adjacent to time \(0\). The boxes display membership in the halves, not separate field copies.
For a real scalar configuration \(\phi \in \mathbb R^X\), write \((\theta \phi )_v=\phi _{\theta v}\). On complex observables define \[(\Theta f)(\phi )=\overline {f(\theta \phi )}.\] Thus \(\Theta \) is an antilinear multiplicative involution. Let \(\mathcal A_+\) be the algebra of bounded complex measurable functions depending only on \(\phi |_{X_+}\). Let \(\mu \) be a probability measure on \(\mathbb R^X\). Reflection invariance means \(\theta _*\mu =\mu \). In addition, reflection positivity means \[B_\mu (f,f):=\int (\Theta f)f\,d\mu \ge 0 \qquad (f\in \mathcal A_+).\] The inequality includes the assertion that the integral is real. Under reflection invariance, \(B_\mu (f,g)=\int (\Theta f)g\,d\mu \) is Hermitian and conjugate-linear in its first argument. These are the complex-observable conventions corresponding to [friedli2017statistical, Definition 10.5, p. 441].
The larger positive-time domain is \(\mathcal H_+=L^2(\mathbb R^X,\mu ;\mathbb C)\) restricted to functions measurable in the coordinates of \(X_+\). It is a closed vector subspace, generally not an algebra under pointwise multiplication. Reflection invariance gives \[|B_\mu (f,g)|\le \|f\|_{L^2(\mu )}\|g\|_{L^2(\mu )}.\] Truncating the values of a function shows that \(\mathcal A_+\) is dense in \(\mathcal H_+\). Consequently positivity on \(\mathcal A_+\) extends to this domain. For a reflection-positive law, the quotient by \(\mathcal N=\{f:B_\mu (f,f)=0\}\), with the induced pairing, has a Hilbert-space completion. This definition supplies no translation operator on that quotient.
Lemma. A sufficient positive-half decomposition [fdip-007N]AGENTDRAFTED
- November 1, 2026
Lemma. A sufficient positive-half decomposition [fdip-007N]AGENTDRAFTED
- November 1, 2026
Let a finite set \(X\) have an involution \(\theta \) and halves \(X_-=\theta X_+\) with \(X_+\cup X_-=X\) and \(X_+\cap X_-=\operatorname {Fix}(\theta )=X_0\). Use the observable conventions of Definition [fdip-007M]; both torus reflections there have these properties. Let \(\nu \) be a probability measure supported on a compact interval of \(\mathbb R\), and put \(\mu _0=\bigotimes _{v\in X}\nu \). Suppose a real Hamiltonian has the form \[-H=A+\Theta A+\sum _{\alpha =1}^q C_\alpha \Theta C_\alpha ,\] where \(A,C_1,\ldots ,C_q\) are bounded real functions in \(\mathcal A_+\); the sum may be empty. Then the probability law \[d\mu =Z^{-1}e^{-H}\,d\mu _0,\qquad Z=\int e^{-H}\,d\mu _0\] is reflection invariant and reflection positive. This is the complex-observable version of [friedli2017statistical, Lemma 10.8, pp. 442–443].
Proof.
- November 1, 2026
Proof.
- November 1, 2026
First consider the product reference. Conditional on the field \(b=\phi |_{X_0}\) at the fixed sites, the two interiors are independent and have matching product laws under reflection. The boundary field is a single shared variable. For any bounded positive-half observable \(F\), therefore, \[\int (\Theta F)F\,d\mu _0 =\int \left |\int F(\phi _+,b)\,d\nu _+(\phi _+)\right |^2 \,d\nu _0(b)\ge 0.\] Here \(\nu _+\) is the product over \(X_+\setminus X_0\) and \(\nu _0\) the product over \(X_0\). When \(X_0\) is empty the outer integral is evaluation at the unique empty configuration. This also proves the product case of [friedli2017statistical, Lemma 10.7, p. 442].
The displayed decomposition is invariant under reflection because its functions are real and multiplication commutes. The reference law is invariant as well. Boundedness makes \(0<Z<\infty \) and permits uniform absolute expansion of the crossing exponential. For \(f\in \mathcal A_+\), this gives \[\begin {aligned} ZB_\mu (f,f) &=\sum _{n\in \mathbb N^q}\frac 1{n!} B_{\mu _0}\left (fe^A C^n,fe^A C^n\right ),\\ n!&=\prod _\alpha n_\alpha !,\qquad C^n=\prod _\alpha C_\alpha ^{n_\alpha }. \end {aligned}\] Every summand is nonnegative by the conditional product identity. The sum converges absolutely by the bounded exponential majorant, so the claimed positivity follows.
Theorem. Reflection positivity of a massive scalar lattice [fdip-007O]AGENTDRAFTED
- November 1, 2026
Theorem. Reflection positivity of a massive scalar lattice [fdip-007O]AGENTDRAFTED
- November 1, 2026
On the nearest-neighbor torus of Definition [fdip-007M], choose either reflection \(\theta \). Give every undirected edge a nonnegative weight \(w_e\) with \(w_{\theta e}=w_e\), and fix \(m>0\). The real scalar law \[\begin {aligned} H(\phi )&=\frac 12\sum _{e=\{u,v\}}w_e(\phi _u-\phi _v)^2 +\frac {m^2}{2}\sum _{v\in X}\phi _v^2,\\ d\mu (\phi )&=Z^{-1}e^{-H(\phi )} \prod _{v\in X}d\phi _v \end {aligned}\] is reflection invariant and reflection positive on \(\mathcal A_+\) and its positive-time \(L^2\) domain. Every polynomial in the positive-half field coordinates belongs to that domain. This is the massive scalar precision with zero-weight edges omitted. It uses ordinary differences, equivalently trivial transport in the connection energy.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Since \(H(\phi )\ge (m^2/2)\|\phi \|^2\), the normalizer is finite and positive, and every polynomial moment exists. Reflection is a permutation of the coordinates, preserves Lebesgue measure and preserves \(H\) by the weight hypothesis. This proves invariance separately from positivity.
For a site reflection, no nearest-neighbor edge joins \(X_+\setminus X_0\) directly to \(X_-\setminus X_0\). Partition the terms of \(H\) into \(H_+\), those supported in \(X_+\) but not wholly in \(X_0\); their reflected partners \(H_-=\Theta H_+\); and \(H_0\), those supported wholly in \(X_0\). Include onsite mass terms in the same partition. Because reflection fixes every boundary coordinate, \[-H=A+\Theta A,\qquad A=-H_+-\tfrac 12H_0.\] In particular the boundary terms are counted once.
For a link reflection the halves are disjoint. The only crossing edges are the time bonds at the two cuts, and each has the form \(e=\{v,\theta v\}\) with a unique \(v\in X_+\). Its contribution to \(-H\) is \[-\frac {w_e}{2}\phi _v^2 -\frac {w_e}{2}\phi _{\theta v}^2 +w_e\phi _v\phi _{\theta v}.\] Put its first term into \(A\), its second into \(\Theta A\), and write the last as \(C_e\Theta C_e\), where \(C_e=\sqrt {w_e}\phi _v\). All within-half edge energies and onsite mass terms are assigned to their own half, with a minus sign. Reflection invariance of the weights then gives the positive-half decomposition.
For \(R>0\), restrict every coordinate to \([-R,R]\) and use the uniform probability on this interval as the product reference. On that cube the functions \(A,C_e\) are bounded, so the lemma proves reflection positivity of the normalized cutoff law \(\mu _R\). The constant reference-density factor cancels from normalization; thus \(\mu _R\) is exactly \(\mu \) conditioned on \(\max _v|\phi _v|\le R\). For bounded \(f,g\), dominated convergence in the integrable Gaussian density gives \[B_{\mu _R}(f,g)\longrightarrow B_\mu (f,g).\] For polynomials the same argument uses a polynomial times the dominating massive Gaussian. In particular positivity survives the limit. Finally, bounded value truncations are dense in \(\mathcal H_+\); the norm bound in Definition [fdip-007M] extends the pairing and its positivity to all of that domain.
Compare [friedli2017statistical, pp. 443–444], Examples 10.9–10.10, for the half decompositions. The cutoff argument above supplies the noncompact Gaussian step. Arbitrary inhomogeneous weights need not respect the chosen reflection. Arbitrary fixed connections need not have the displayed nonnegative crossing terms. Neither case is asserted by this theorem.
Example. The two-site reflection Gram matrix [fdip-007P]AGENTDRAFTED
- November 1, 2026
Example. The two-site reflection Gram matrix [fdip-007P]AGENTDRAFTED
- November 1, 2026
Take two real field coordinates \(x,y\), interchanged by reflection, and the centered Gaussian precision \[Q=\begin {pmatrix}a&-w\\-w&a\end {pmatrix}, \qquad a>|w|.\] The positive-half observables depend on \(x\). The covariance is \[G=Q^{-1} =\frac 1{a^2-w^2}\begin {pmatrix}a&w\\w&a\end {pmatrix}.\] For \(a=2,w=1\), this becomes \[G=\begin {pmatrix}2/3&1/3\\1/3&2/3\end {pmatrix}.\] The energy has positive mass squared \(a-w=1\) and crossing weight \(w=1\), so the same cutoff criterion proves reflection positivity.
For \(f_0=1,f_1=x,f_2=x^2\), the reflection Gram matrix is \[\left (B_\mu (f_j,f_k)\right )_{j,k=0}^2 =\begin {pmatrix} 1&0&2/3\\ 0&1/3&0\\ 2/3&0&2/3 \end {pmatrix}.\] Odd Gaussian moments vanish, and \(\mathbb E[x^2y^2]=(2/3)^2+2(1/3)^2=2/3\) by the four-factor Gaussian calculation. The leading principal minors are \(1\), \(1/3\) and \(2/27\), so this finite Gram matrix is positive definite. Positivity of this one matrix is an illustration; the criterion proves the claim for all positive-half observables.
TauCeti's
TauCeti.Probability.integral_mul_mul_mul_multivariateGaussian
proves the fourth-moment identity for a finite coordinate index set
and a positive-semidefinite covariance, including repeated indices.
Apply it with the displayed \(G\) and indices \(x,x,y,y\).
This correspondence supports the moment calculation; the reflected
pairing and its Gram-matrix positivity are computed here.
If instead \(a=2,w=-1\), the precision remains positive definite and its Gaussian remains reflection invariant. But \[B_\mu (x,x)=\mathbb E[xy]=-\frac 13<0.\] Thus reflection invariance and ordinary Gaussian positivity do not imply reflection positivity. The witness \(x\) is square-integrable; bounded value truncations also have a negative pairing once the cutoff is large enough, by continuity of \(B_\mu \).
Example. Reflection positivity without a quotient time shift [fdip-007Q]AGENTDRAFTED
- November 1, 2026
Example. Reflection positivity without a quotient time shift [fdip-007Q]AGENTDRAFTED
- November 1, 2026
On time sites \(\mathbb Z/6\), let \(\phi _t\) be independent centered real Gaussians with variances \[(v_0,v_1,v_2,v_3,v_4,v_5)=(1,1,2,3,3,2).\] Use the link reflection \(\theta (t)=1-t\) and positive half \(X_+=\{1,2,3\}\). Since \(v_{\theta t}=v_t\), the product law is reflection invariant. The halves are independent and their laws agree under reflection, so for every positive-half square-integrable \(F\), \[B_\mu (F,F)=|\mathbb E_\mu F|^2\ge 0.\] This proves reflection positivity directly, without a translation-invariance assumption.
Define a one-step shift of a coordinate expression by replacing each \(\phi _t\) by \(\phi _{t+1}\). On expressions whose sites remain in \(X_+\), this at least gives another positive-half function. In particular, \[F=\phi _1^2-1,\qquad \tau F=\phi _2^2-1\] both belong to the positive-time \(L^2\) domain. Their pairings are \[B_\mu (F,F)=0,\qquad B_\mu (\tau F,\tau F)=1.\] Indeed their expectations are \(v_1-1=0\) and \(v_2-1=1\). The centering constant is part of the shifted expression and does not change from \(1\) to \(v_2\).
Thus a zero vector in the reflection quotient would be sent to a nonzero one. The shift cannot descend even on this pair of positive-half polynomials. A transfer operator requires additional structure; reflection positivity alone does not construct it.
Remark. The scalar result and the gauge transfer question [fdip-007R]AGENTDRAFTED
- November 1, 2026
Remark. The scalar result and the gauge transfer question [fdip-007R]AGENTDRAFTED
- November 1, 2026
The sufficient criterion here comes from the compact-spin argument of Friedli–Velenik [friedli2017statistical, Lemma 10.8, pp. 442–443], with an explicit Gaussian cutoff passage. It concerns an ordinary scalar field with a chosen reflection. The classical small-spacing expansion of the Wilson action supplies no reflection-positive probability law by itself. Nor does integrating matter into a connection marginal establish such a property.
For gauge fields, the positive-character kernel conditions give a different starting point for an explicit finite-volume transfer construction. One must specify the convolution kernel, gauge projection and time-boundary convention and prove the operator properties. The failure of a quotient shift explains why those steps cannot be replaced by reflection positivity alone.
Osterwalder–Seiler [osterwalder1978gauge] provides historical context for gauge and fermion positivity. It is cited here for that context only; no theorem or proof from it is used to extend the scalar result. General gauge–fermion reflection positivity, an infinite-time vacuum construction and continuum reconstruction require separate hypotheses and arguments. Time here remains a chosen lattice direction, rather than an additional field observable.
Transfer operators of the Gaussian chain [fdip-007S]AGENTDRAFTED
- November 1, 2026
Transfer operators of the Gaussian chain [fdip-007S]AGENTDRAFTED
- November 1, 2026
A nearest-neighbor Gaussian energy factors into kernels between successive time slices. Composing those kernels gives a transfer operator; closing the chain gives its trace. For a single real field per slice, Hermite functions diagonalize the operator exactly. The leading eigenvalue fixes the normalization needed before its logarithm becomes a nonnegative Hamiltonian.
The construction uses positive weight and mass, Lebesgue measure on each field coordinate and a unit time step. It supplies the operator structure that reflection positivity alone does not determine. The cycle determinant and periodic covariance give independent finite-dimensional checks of its partition function and field correlations.
Definition. The one-step Gaussian kernel [fdip-007T]AGENTDRAFTED
- November 1, 2026
Definition. The one-step Gaussian kernel [fdip-007T]AGENTDRAFTED
- November 1, 2026
Fix \(w>0\) and \(m>0\). On \(\mathcal H=L^2(\mathbb R,dx;\mathbb C)\), define the Gaussian transfer operator by \[\begin {aligned} K(x,y)&=\exp \left [-\frac w2(x-y)^2 -\frac {m^2}{4}(x^2+y^2)\right ],\\ (Tf)(x)&=\int _{\mathbb R}K(x,y)f(y)\,dy. \end {aligned}\] The reference measure is exactly Lebesgue measure \(dy\); no normalizing factor is included in \(K\). This is the one-coordinate instance of the slice-kernel construction in [wingate2025lattice, Eqs. (5.1)–(5.3), p. 4].
Write \(a=w/2+m^2/4\), so \(K(x,y)=e^{-a(x^2+y^2)+wxy}\) and \(2a>w\). Thus \(K\in L^2(\mathbb R^2)\). Cauchy–Schwarz makes \(T\) bounded, and symmetry of the real kernel makes it self-adjoint. An integral operator with a square-integrable kernel is Hilbert–Schmidt: in an orthonormal basis \((e_n)\), its squared norm of this kind is \(\|T\|_{\mathrm {HS}}^2=\sum _n\|Te_n\|^2\) (the value is independent of the basis). Here it equals \(\int |K|^2\). Approximation of \(K\) by finite sums of products of one-variable square-integrable functions also shows that \(T\) is compact. Operator positivity will follow from its explicit spectrum in Theorem [fdip-007U].
For \(N\ge 3\), let \(x_N=x_0\) and define the periodic chain by \[\begin {aligned} H_N(x)&=\frac w2\sum _{j=0}^{N-1}(x_{j+1}-x_j)^2 +\frac {m^2}{2}\sum _{j=0}^{N-1}x_j^2,\\ Z_N&=\int _{\mathbb R^N}e^{-H_N(x)}\,d^Nx,\qquad d\mu _N=Z_N^{-1}e^{-H_N(x)}\,d^Nx. \end {aligned}\] Each undirected edge of the ordinary cycle \(C_N\) occurs once. Splitting each onsite mass term between its two incident edges gives \[e^{-H_N(x)}=\prod _{j=0}^{N-1}K(x_j,x_{j+1}).\] Positive mass makes \(0<Z_N<\infty \). The identity \(Z_N=\operatorname {Tr}T^N\) is proved in Theorem [fdip-007V].
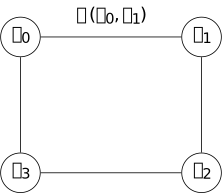
The four-cycle illustrates the kernel product. Every edge contributes the same function \(K\) of its endpoints. Each site's two mass contributions add to \(m^2x_j^2/2\); closing the last edge identifies \(x_4\) with \(x_0\).
Theorem. Hermite diagonalization [fdip-007U]AGENTDRAFTED
- November 1, 2026
Theorem. Hermite diagonalization [fdip-007U]AGENTDRAFTED
- November 1, 2026
For the Gaussian transfer operator, define \[\begin {aligned} \cosh \omega &=1+\frac {m^2}{2w},& \omega &>0,\\ q&=e^{-\omega },& s&=w\sinh \omega ,\\ \lambda _0&=\sqrt {\frac {2\pi }{w}}e^{-\omega /2}. \end {aligned}\] Define the probabilists' Hermite polynomials \(\operatorname {He}_n\) by the generating function \[e^{uz-z^2/2} =\sum _{n=0}^\infty \operatorname {He}_n(u)\frac {z^n}{n!},\] and put \[h_n^s(x)=\left (\frac {s}{\pi }\right )^{1/4} \frac {\operatorname {He}_n(\sqrt {2s}\,x)}{\sqrt {n!}} e^{-sx^2/2}.\] These functions form an orthonormal basis of \(L^2(\mathbb R,dx;\mathbb C)\), and \[Th_n^s=\lambda _0q^nh_n^s\qquad (n\ge 0).\] Consequently \(T\) is positive, injective and trace class, with \(\|T\|=\lambda _0\) and \(\operatorname {Tr}T=\lambda _0/(1-q)\). The normalized operator \(\widehat T=T/\lambda _0\) is an injective positive contraction.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
First establish the basis. Integrating two generating functions against \(e^{-sx^2}\) gives \[\begin {aligned} &\int _{\mathbb R}e^{-sx^2} e^{\sqrt {2s}\,xz-z^2/2} e^{\sqrt {2s}\,xt-t^2/2}\,dx\\ &\hspace {20mm}=\sqrt {\frac \pi s}\,e^{zt}. \end {aligned}\] Differentiation at \(z=t=0\) proves orthogonality with precisely the displayed normalization. Every such differentiation is justified by a polynomial times an integrable Gaussian, uniformly for the complex parameters in a compact set.
For completeness, suppose \(f\in L^2\) is orthogonal to every \(h_n^s\). Since \(\operatorname {He}_n\) has degree \(n\) and leading coefficient one, all moments of \(g(x)=f(x)e^{-sx^2/2}\) vanish. Cauchy–Schwarz shows that \(g\in L^1\) and that \[F(z)=\int _{\mathbb R}g(x)e^{zx}\,dx\] is entire: on every compact set of complex \(z\), all derivative integrands have an integrable majorant of the form \(|f(x)|\,|x|^k e^{-sx^2/2+R|x|}\). All Taylor coefficients of \(F\) vanish, so \(F=0\); in particular the Fourier transform of \(g\) vanishes. To see the needed uniqueness directly, convolve \(g\) with a normalized Gaussian. The Gaussian Fourier integral and Fubini express this convolution as an integral of its zero Fourier transform, hence it is zero. As the Gaussian variance tends to zero, these convolutions tend to \(g\) in \(L^1\), by continuity of translations in \(L^1\) and dominated convergence. Thus \(g=0\) almost everywhere and \(f=0\). The orthonormal family is complete.
Now diagonalize the kernel. With \(a=w\cosh \omega /2\), the identities \(s=w\sinh \omega \) and \(a+s/2=w/(2q)\) give, by completing the square in \(y\), \[\begin {aligned} &\int _{\mathbb R}K(x,y)e^{-sy^2/2} e^{\sqrt {2s}\,yz-z^2/2}\,dy\\ &\hspace {8mm}=\lambda _0e^{-sx^2/2} e^{\sqrt {2s}\,xqz-q^2z^2/2}. \end {aligned}\] The constant is \(\sqrt {\pi /(a+s/2)}=\sqrt {2\pi q/w}=\lambda _0\). Differentiating \(n\) times at zero, again under a Gaussian majorant, gives \(Th_n^s=\lambda _0q^nh_n^s\).
If \(f=\sum _n c_nh_n^s\), boundedness and completeness give \[Tf=\sum _{n=0}^\infty \lambda _0q^nc_nh_n^s\] in \(L^2\). Every eigenvalue is strictly positive, which proves positivity and injectivity. Their maximum is \(\lambda _0\). For a positive compact operator, being trace class means that these eigenvalues have finite sum; here the sum is \(\lambda _0/(1-q)\). This proves all operator assertions. It also gives the Mehler kernel expansion \[K(x,y)=\sum _{n=0}^\infty \lambda _0q^nh_n^s(x)h_n^s(y)\] in \(L^2(\mathbb R^2)\): the squared Hilbert–Schmidt norm of the tail is \(\lambda _0^2\sum _{n>r}q^{2n}\) after truncation at \(r\). This convergence statement suffices for the operator identity.
The calculation is a direct diagonalization of
Definition [fdip-007T]. TauCeti's
TauCeti.hermiteHilbertBasis and
TauCeti.coe_hermiteHilbertBasis
supply the complete orthonormal Hermite basis at \(s=1\), with
exactly the probabilists' normalization used here. The unitary
dilation \(f(x)\mapsto s^{1/4}f(\sqrt {s}\,x)\) gives the displayed
basis for general \(s>0\). These references support the basis;
the kernel eigenvalues and transfer properties are proved above.
Example. A transfer norm greater than one [fdip-007X]AGENTDRAFTED
- November 1, 2026
Example. A transfer norm greater than one [fdip-007X]AGENTDRAFTED
- November 1, 2026
Take \(w=3/2\) and \(m^2=4/5\) in Theorem [fdip-007U]. Then \[\begin {aligned} \cosh \omega &=\frac {19}{15},& s&=\frac {\sqrt {34}}5,\\ q&=\frac {19-2\sqrt {34}}{15},& \lambda _0&=\sqrt {\frac {4\pi q}{3}}. \end {aligned}\] Numerically \(\omega \approx 0.714971\) and \(\lambda _0\approx 1.431497\). In particular \(\|T\|=\lambda _0>1\). This inequality does not depend on rounding: \(\sqrt {34}<6\) gives \(q>7/15\), and \(\pi >3\) gives \(\lambda _0^2>28/15>1\).
All eigenvalues are nevertheless positive: \(\lambda _n=\lambda _0q^n\). Dividing by the leading eigenvalue gives \(\widehat T h_n^s=q^nh_n^s\) and \(\|\widehat T\|=1\). The lowest mode label \(n=0\) refers to the Gaussian function \(h_0^s\), not to a constant function on \(\mathbb R\); the latter does not belong to Lebesgue \(L^2\). Thus the normalization is a genuine scalar factor in the operator, fixed by the chosen reference measure.
Theorem. Periodic traces and field correlations [fdip-007V]AGENTDRAFTED
- November 1, 2026
Theorem. Periodic traces and field correlations [fdip-007V]AGENTDRAFTED
- November 1, 2026
Use the kernel and parameters of Definition [fdip-007T] and Theorem [fdip-007U]. For every integer \(N\ge 1\), \[\operatorname {Tr}T^N =\frac {\lambda _0^N}{1-q^N} =\frac {(2\pi /w)^{N/2}}{2\sinh (N\omega /2)}.\] For \(N\ge 3\), this equals the periodic Gaussian normalizer \(Z_N\). If \(f_0,\ldots ,f_{N-1}\) are bounded complex measurable functions and \(M_f\) denotes multiplication by \(f\), then \[\mathbb E_{\mu _N}\prod _{j=0}^{N-1}f_j(x_j) =\frac {\operatorname {Tr} (M_{f_0}T M_{f_1}T\cdots M_{f_{N-1}}T)}{Z_N}.\] In particular, bounded two-point observables have the usual cyclic trace expression with \(T^{N-t}\) and \(T^t\).
For \(N\ge 3\) and the unbounded coordinate observable, let \(Xf(x)=xf(x)\) on its domain \(\{f\in L^2:xf\in L^2\}\). For integers \(0\le t\le N\), initially on finite Hermite sums, put \[A_t=T^{t/2}XT^{(N-t)/2}.\] It has a unique Hilbert–Schmidt extension. The precise coordinate trace formula is \[\begin {aligned} \mathbb E_{\mu _N}[x_0x_t] &=\frac {\operatorname {Tr}(A_t^*A_t)}{Z_N}\\ &=\frac {q^t+q^{N-t}}{2s(1-q^N)}, \qquad x_N=x_0. \end {aligned}\] Here \(\operatorname {Tr}(A_t^*A_t)\) supplies the meaning of the frequently written unbounded expression \(\operatorname {Tr}(T^{N-t}XT^tX)\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The eigenvalues in Theorem [fdip-007U] give the first trace by a geometric sum. The remaining expression uses \(\lambda _0=\sqrt {2\pi /w}\,q^{1/2}\) and \(q^{-N/2}-q^{N/2}=2\sinh (N\omega /2)\). On the ordinary cycle, the precision is \(Q_N=m^2I+wL_{C_N}\). The twisted-cycle determinant at trivial holonomy, with the scalar factor \(w\) restored, gives \[\det Q_N=w^N\bigl (2\cosh (N\omega )-2\bigr ).\] The real Gaussian integral therefore gives exactly the same \(Z_N\). The trace identity for \(N=1,2\) remains an operator identity; no ordinary simple-cycle identification is used for those two periods.
For bounded insertions, \(M_fT\) is Hilbert–Schmidt. The product of two such operators is trace class; multiplying by the remaining bounded factors preserves this property. The Hilbert–Schmidt kernel trace identity \[\operatorname {Tr}(AB)=\int _{\mathbb R^2}A(x,y)B(y,x)\,dx\,dy\] follows by expanding the two kernels in an orthonormal basis and taking their \(L^2\) pairing. Applying it to the cyclic product and composing the intervening kernels yields \[\operatorname {Tr}(M_{f_0}T\cdots M_{f_{N-1}}T) =\int _{\mathbb R^N}\prod _j f_j(x_j) \prod _jK(x_j,x_{j+1})\,d^Nx.\] All repeated integrals are absolutely convergent: the absolute integrand is bounded by \(\prod _j\|f_j\|_\infty \) times the integrable massive Gaussian. The kernel factorization in Definition [fdip-007T] proves the asserted expectation.
For the coordinate insertion, the Hermite generating function gives the recurrence \[Xh_n^s=\frac {\sqrt {n+1}\,h_{n+1}^s +\sqrt n\,h_{n-1}^s}{\sqrt {2s}},\] where the second term is zero at \(n=0\). Consequently the matrix of \(A_t\) has only two adjacent diagonals. Summing their squared entries gives \[\begin {aligned} \|A_t\|_{\mathrm {HS}}^2 &=\frac {\lambda _0^N}{2s} \frac {q^t+q^{N-t}}{(1-q^N)^2}. \end {aligned}\] The sum is finite also at \(t=0,N\). Thus the operator on the dense finite Hermite span extends uniquely to a Hilbert–Schmidt operator. Thus \(A_t^*A_t\) is positive trace class and its trace is this squared norm. Division by \(Z_N\) gives the displayed value. Finally, the periodic covariance calculation, with \(s=w\sinh \omega \), gives this same value for \((Q_N^{-1})_{0t}\). Gaussian covariance therefore identifies it with \(\mathbb E_{\mu _N}[x_0x_t]\), including the periodic endpoint. No cyclic manipulation of an undefined unbounded product is used.
This finite periodic calculation makes the trace notation of [wingate2025lattice, Eq. (5.4), p. 4] explicit for the Gaussian chain. That source subsequently takes an infinite-time limit; the identities here hold at finite \(N\). The Ising transfer and Markov-chain comparison in [friedli2017statistical, Section 3.10.4, p. 139] concerns a different state space and is background for the transfer interpretation, not a premise for this Gaussian proof.
Corollary. The oscillator Hamiltonian [fdip-007W]AGENTDRAFTED
- November 1, 2026
Corollary. The oscillator Hamiltonian [fdip-007W]AGENTDRAFTED
- November 1, 2026
For the normalized transfer operator \(\widehat T=T/\lambda _0\) of Theorem [fdip-007U], the transfer Hamiltonian is the spectral logarithm \(H=-\log \widehat T\). Explicitly, if \(f=\sum _{n\ge 0}c_nh_n^s\), its domain and action are \[\begin {aligned} D(H)&=\left \{f:\sum _{n=0}^\infty (n\omega )^2|c_n|^2<\infty \right \},\\ Hf&=\sum _{n=0}^\infty n\omega c_nh_n^s. \end {aligned}\] It is nonnegative and self-adjoint, with eigenvalues \(n\omega \). Its zero eigenspace is the line spanned by \(h_0^s\), and its mass gap is \(\omega \). It is unbounded even though \(\widehat T\) is bounded and injective.
On the finite Hermite span, it has the differential expression \[Hf=\frac \omega {2s} \left (-f''+s^2x^2f-sf\right ).\] The closure of this expression on that span is the above spectral operator. This is the harmonic oscillator with its ground energy subtracted. The time step has length one; a specified step \(a_t>0\) instead gives \(H/a_t\) and gap \(\omega /a_t\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The unitary coefficient map \(f\mapsto (c_n)\) identifies \(\widehat T\) with multiplication by \(q^n>0\) on \(\ell ^2\). Its negative logarithm is multiplication by \(n\omega \) on the stated maximal domain. A real diagonal operator on that domain is self-adjoint; its quadratic form is nonnegative. The listed eigenspaces, spectrum and gap follow directly, and \(\|Hh_n^s\|=n\omega \) proves unboundedness. Finite coefficient truncations converge both in norm and after applying \(H\), so the finite Hermite span is a core.
Differentiating the Hermite generating function and comparing coefficients gives \(\operatorname {He}_n''(u)-u\operatorname {He}_n'(u) +n\operatorname {He}_n(u)=0\). Substitution into the definition of \(h_n^s\) yields \[-(h_n^s)''+s^2x^2h_n^s=(2n+1)s\,h_n^s.\] The displayed differential expression therefore acts as \(n\omega \) on every basis vector. The core statement proves that its closure is exactly \(H\).
TauCeti's
TauCeti.hermiteFunction_oscillator
proves the pointwise differential identity at \(s=1\) for the
same normalized Hermite functions. Dilation gives the identity
above for \(s>0\); the spectral logarithm, its domain and the
closure statement are supplied by the preceding argument.
The logarithmic prescription follows [wingate2025lattice, Eq. (5.5), p. 4], with the leading transfer eigenvalue removed explicitly. It constructs the Hamiltonian for a Gaussian model of finite spatial volume. No limit in time, spatial volume or lattice spacing is needed.
Gauge transfer operators at finite volume [fdip-007Y]AGENTDRAFTED
- November 1, 2026
Gauge transfer operators at finite volume [fdip-007Y]AGENTDRAFTED
- November 1, 2026
A positive character expansion turns a temporal plaquette weight into a positive operator on spatial link fields. Multiplication by half of the spatial weight on each side gives a transfer operator. Gauge averaging selects its physical states and retains the temporal links when the time direction closes into a circle.
The construction uses a finite spatial graph, normalized Haar measure and the positive kernel hypotheses. It proves finite periodic-time trace identities, a spectral Hamiltonian and link-reflected positivity for bounded spatial observables. The Gaussian transfer construction supplies the scalar comparison; reflection positivity by itself does not supply these operator and translation data.
Definition. Spatial link fields and their transfer kernel [fdip-007Z]AGENTDRAFTED
- November 1, 2026
Definition. Spatial link fields and their transfer kernel [fdip-007Z]AGENTDRAFTED
- November 1, 2026
Let \(G\) be a finite group, \(U(1)\) or \(SU(2)\), with normalized Haar measure. Fix a finite incidence presentation with vertex set \(V_s\), oriented edge set \(E_s\) and source and target maps \(s,t:E_s\to V_s\). The spatial configuration space and link Hilbert space are \[X=G^{E_s},\qquad \mathcal H_{\mathrm {link}}=L^2(X,dU;\mathbb C),\] where \(dU\) is product Haar probability measure. The gauge action of \(K=G^{V_s}\) is \[(h\cdot U)_e=h_{t(e)}U_eh_{s(e)}^{-1},\qquad (R_hf)(U)=f(h^{-1}\cdot U).\] Haar invariance makes every \(R_h\) unitary.
Choose a real continuous central kernel \(k\) satisfying the positive coefficient conditions: \[\begin {gathered} k(g)>0,\qquad k(g^{-1})=k(g),\\ k(g)=\sum _{\rho \in \widehat G}d_\rho a_\rho \chi _\rho (g), \qquad a_\rho >0,\qquad \sum _{\rho \in \widehat G}d_\rho ^2a_\rho <\infty . \end {gathered}\] All irreducible representations here are complex and unitary. The expansion is uniformly absolutely convergent. Pointwise positivity and coefficient positivity are separate hypotheses.
Let \(V:X\to \mathbb R\) be continuous and gauge invariant, and set \(b(U)=e^{-V(U)/2}\). Compactness makes \(b\) and \(b^{-1}\) bounded. If \(M_b\) denotes multiplication by \(b\), define \[\begin {aligned} c(U,U')&=\prod _{e\in E_s}k(U_eU_e'^{-1}),\\ (C_kf)(U)&=\int _Xc(U,U')f(U')\,dU',\\ T&=M_bC_kM_b. \end {aligned}\] This is the pure-gauge transfer operator for the specified data. Its integral kernel is \(b(U)c(U,U')b(U')\). The spatial potential may be a sum of Wilson plaquette terms, but the definition only needs its stated invariance and continuity.
The factorization separates the two spatial half-weights from the temporal convolution. It parallels the gauge factors in [luscher1977transfer, Eqs. (17), (20)–(21), p. 287]; the source comparison distinguishes this pure-gauge model from that paper's gauge and fermion construction.
Example. Positive temporal weights for signs and phases [fdip-0081]AGENTDRAFTED
- November 1, 2026
Example. Positive temporal weights for signs and phases [fdip-0081]AGENTDRAFTED
- November 1, 2026
The transfer kernel conditions have elementary examples. For \(G=\mathbb Z_2=\{1,-1\}\) and \(\beta >0\), take \(k(u)=e^{\beta u}\). The two characters are \(1\) and \(u\), and \[k(u)=\cosh \beta +u\sinh \beta .\] Thus \(a_{\mathrm {triv}}=\cosh \beta >0\) and \(a_{\mathrm {sgn}}=\sinh \beta >0\). Both dimensions are one, so the coefficient sum is \(e^\beta \). The function is real, strictly positive and invariant under inversion.
For \(G=U(1)\), the Wilson and Villain weights give two choices: \[\begin {aligned} k_W(e^{i\theta })&=e^{\beta \cos \theta }, &a_n^W&=I_n(\beta ),\\ k_V(e^{i\theta })&=\sum _{\ell \in \mathbb Z} e^{-\beta _V(\theta -2\pi \ell )^2/2}, &a_n^V&=\frac {e^{-n^2/(2\beta _V)}}{\sqrt {2\pi \beta _V}}. \end {aligned}\] Here \(\beta ,\beta _V>0\) and \(n\in \mathbb Z\). All coefficients are positive and summable; all characters have dimension one. The cited calculation proves the series, continuity and inversion symmetry. Each function is strictly positive from its definition, so every hypothesis is met. These are unnormalized weights; no zeroth coefficient has been divided out.
At \(\beta =0\), the sign or Wilson weight is constant and its nontrivial Fourier coefficients vanish. The resulting convolution kills nonconstant modes, so strict coefficient positivity cannot be removed from the injectivity assertion in Theorem [fdip-0080].
Proposition. A positive coefficient expansion on SU(2) [fdip-0082]AGENTDRAFTED
- November 1, 2026
Proposition. A positive coefficient expansion on SU(2) [fdip-0082]AGENTDRAFTED
- November 1, 2026
Let \(f\) be the defining two-dimensional representation of \(SU(2)\) and \(\beta >0\). Then \[k(g)=e^{\beta \chi _f(g)}\] satisfies the transfer kernel conditions. More precisely, if \(m_\rho (n)\) is the multiplicity of \(\rho \) in \(f^{\otimes n}\), then \[\begin {aligned} c_\rho &=\sum _{n=0}^\infty \frac {\beta ^n}{n!}m_\rho (n)>0,\\ a_\rho &=\frac {c_\rho }{d_\rho },\qquad \sum _\rho d_\rho ^2a_\rho =e^{2\beta }. \end {aligned}\] This is the tensor-power argument used in [luscher1977transfer, Proposition 1, p. 288], with strict occurrence and absolute convergence justified below.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The matrix description of SU(2) writes its elements as \[g=\begin {pmatrix}z&w\\-\overline w&\overline z\end {pmatrix}, \qquad |z|^2+|w|^2=1.\] Hence \(\chi _f(g)=2\operatorname {Re}z\) is real, \(\chi _f(g^{-1})=\chi _f(g)\), and \(k\) is continuous, central and strictly positive. Every tensor power is unitary; invariant orthogonal complements decompose it into irreducibles. Therefore \[\chi _f(g)^n=\sum _\rho m_\rho (n)\chi _\rho (g), \qquad \sum _\rho m_\rho (n)d_\rho =2^n.\] Expanding the exponential and using nonnegative multiplicities gives \[\sum _\rho d_\rho c_\rho =\sum _{n=0}^\infty \frac {\beta ^n2^n}{n!}=e^{2\beta }.\] Since \(|\chi _\rho (g)|\le d_\rho \), this also justifies rearranging the series uniformly and proves the claimed expansion. It remains to show that no \(c_\rho \) is zero.
Consider the algebra of finite linear combinations of matrix
coefficients of the powers \(f^{\otimes n}\), including \(n=0\).
Products are coefficients of tensor products, so this is a unital
algebra of continuous functions. The entries of \(g\) distinguish
its points. Their complex conjugates are again entries up to a
sign, by the displayed matrix form, so the algebra is closed under
complex conjugation. The complex Stone–Weierstrass theorem makes
it uniformly dense in \(C(SU(2),\mathbb C)\). Here that analytic
theorem is used as a cited statement: a conjugation-closed unital
subalgebra of continuous complex functions on a compact space is
dense if it separates points. Its exact formal statement is
ContinuousMap.starSubalgebra_topologicalClosure_eq_top_of_separatesPoints.
The reference supplies this density theorem, not the representation
argument that follows.
If an irreducible \(\rho \) occurred in no tensor power, Schur orthogonality from the Peter–Weyl theorem would make all its matrix coefficients orthogonal to this algebra. Choose a nonzero such coefficient \(u\). Uniform density gives algebra functions converging uniformly, hence in normalized Haar \(L^2\), to \(u\). Orthogonality would then give \(\|u\|_2^2=0\), a contradiction. Thus \(m_\rho (n)>0\) for some \(n\), and \(\beta >0\) makes \(c_\rho >0\). Dividing by \(d_\rho \) proves all remaining coefficient assertions.
Theorem. Positivity and trace class of the gauge transfer operator [fdip-0080]AGENTDRAFTED
- November 1, 2026
Theorem. Positivity and trace class of the gauge transfer operator [fdip-0080]AGENTDRAFTED
- November 1, 2026
For the spatial transfer data, \(C_k\) and \(T=M_bC_kM_b\) are bounded, self-adjoint, positive, injective and trace class. Both commute with every gauge operator \(R_h\). If \[\kappa =\sum _\rho d_\rho ^2a_\rho =k(1),\] then \[\operatorname {Tr}C_k=\kappa ^{|E_s|},\qquad \operatorname {Tr}T\le \|b\|_\infty ^2\kappa ^{|E_s|}.\] Positive means \(\langle f,Tf\rangle \ge 0\); in fact this pairing is strictly positive for every nonzero \(f\). It does not assert a uniform positive lower bound on the spectrum.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For one edge, use the normalized matrix-entry basis \(\phi _{\rho ij}(U)=\sqrt {d_\rho }\rho (U)_{ij}\) of the Peter–Weyl theorem. Unitarity gives \[k(UU'^{-1})=\sum _{\rho ,i,j} a_\rho \phi _{\rho ij}(U)\overline {\phi _{\rho ij}(U')}.\] Indeed, the matrix-entry sum is \(d_\rho \operatorname {Tr}(\rho (U)\rho (U')^*)\). Schur orthogonality therefore makes convolution act by \(a_\rho \) on this block. The tensor products of these bases over the finitely many edges give an orthonormal basis \((\phi _I)\) of \(\mathcal H_{\mathrm {link}}\), with eigenvalues \[\alpha _I=\prod _{e\in E_s}a_{\rho _e}>0,\qquad \sum _I\alpha _I=\kappa ^{|E_s|}<\infty .\] The operator assertions about \(C_k\), including injectivity and its trace, follow directly from this complete diagonalization. Here trace class for a positive compact operator has the meaning used in the Gaussian spectrum: its eigenvalues are summable.
For clarity, write the rank-one operator \(|v\rangle \langle v|\) as \(f\mapsto v\langle v,f\rangle \), with the inner product linear in its second variable. Then \[T=\sum _I\alpha _I |b\phi _I\rangle \langle b\phi _I|.\] The trace norm is \(\|A\|_1=\operatorname {Tr}((A^*A)^{1/2})\); for a positive operator it equals its trace. Trace class means this norm is finite. Each summand is positive and its trace norm is \(\alpha _I\|b\phi _I\|_2^2\). Their sum is at most \(\|b\|_\infty ^2\sum _I\alpha _I\), so the series converges in trace norm and proves positivity, self-adjointness, compactness and the trace bound. For \(f\ne 0\), bounded invertibility of \(M_b\) gives \(bf\ne 0\); hence \[\langle f,Tf\rangle =\langle bf,C_kbf\rangle >0.\] This proves injectivity as well.
Under a simultaneous gauge change of \(U,U'\), \[(h\cdot U)_e(h\cdot U')_e^{-1} =h_{t(e)}(U_eU_e'^{-1})h_{t(e)}^{-1}.\] Centrality of \(k\) and invariance of product Haar measure show \(C_kR_h=R_hC_k\). Gauge invariance of \(b\) gives the same commutation for \(M_b\) and \(T\).
The coefficient calculation is a direct application of
Peter–Weyl orthogonality. TauCeti's
TauCeti.peterWeylBlockAveraging_eq_starProjection
identifies character averaging with the corresponding orthogonal
block projection. Its kernel is \(d_\rho \overline {\chi _\rho }\)
and its matrix-coefficient convention is the conjugated one
explained in Theorem [fdip-007C]. Reindexing by dual representations
aligns the conventions; reality and inversion symmetry give
\(a_{\overline \rho }=a_\rho \). This correspondence concerns the
block projection, while the positive weighted sum and spatial
multipliers are proved above.
The factorization proof follows the idea of [luscher1977transfer, Proposition 1, p. 288], under the explicit pure-gauge hypotheses of Definition [fdip-007Z].
Theorem. Gauge projection and periodic-time traces [fdip-0083]AGENTDRAFTED
- November 1, 2026
Theorem. Gauge projection and periodic-time traces [fdip-0083]AGENTDRAFTED
- November 1, 2026
For the spatial transfer data, normalized gauge averaging is the orthogonal projection \[\begin {aligned} (Pf)(U)&=\int _K f(h^{-1}\cdot U)\,dh,\\ \mathcal H_{\mathrm {phys}} &=\{f:R_hf=f\text { for every }h\in K\}=P\mathcal H_{\mathrm {link}}. \end {aligned}\] This defines the physical Hilbert space of neutral states. The restriction \(T_{\mathrm {phys}}=T|_{\mathcal H_{\mathrm {phys}}}\) is positive, injective and trace class. It is nonzero since constants belong to \(\mathcal H_{\mathrm {phys}}\). For every integer \(N\ge 1\), \[Z_N=\operatorname {Tr}_{\mathrm {phys}}T_{\mathrm {phys}}^N =\operatorname {Tr}_{\mathrm {link}}(PT^N)>0.\] The gauge projector is part of the periodic trace.
There is an explicit lattice integral for \(Z_N\). Put \(U_N=U_0\), take independent variables \(U_j\in X\) and \(h_j\in K\) for \(0\le j<N\), and define \[\begin {aligned} B_{j,e}&=U_{j,e}h_{j,s(e)}U_{j+1,e}^{-1}h_{j,t(e)}^{-1},\\ \mathcal W_N(U,h)&= \prod _{j=0}^{N-1}e^{-V(U_j)} \prod _{j=0}^{N-1}\prod _{e\in E_s}k(B_{j,e}). \end {aligned}\] Then, with normalized product Haar measures, \[Z_N=\int _{X^N\times K^N}\mathcal W_N(U,h)\,dU\,dh.\] Thus \(Z_N^{-1}\mathcal W_N\,dU\,dh\) is a probability law. The temporal link \(h_{j,v}\) transports from time \(j+1\) back to time \(j\). For \(N=1,2\), the formula retains the indexed temporal steps; it does not identify them with edges of an ordinary simple cycle.
For independent gauge changes \(g_j\in K\), with \(g_N=g_0\), the transformations are \[\begin {aligned} U_j&\longmapsto g_j\cdot U_j,\\ h_{j,v}&\longmapsto g_{j,v}h_{j,v}g_{j+1,v}^{-1}. \end {aligned}\] Each \(B_{j,e}\) is conjugated by \(g_{j,t(e)}\). Therefore the weight and measure are invariant. If \(f_j:X\to \mathbb C\) are bounded measurable gauge-invariant functions, multiplication by \(f_j\) preserves \(\mathcal H_{\mathrm {phys}}\), and \[\mathbb E_N\prod _{j=0}^{N-1}f_j(U_j) =\frac {\operatorname {Tr}_{\mathrm {phys}} (M_{f_0}T_{\mathrm {phys}}\cdots M_{f_{N-1}}T_{\mathrm {phys}})}{Z_N}.\] This is a finite periodic-time identity for the specified spatial observables, with the temporal links integrated as above.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Fubini and Jensen define \(P\) on \(L^2\) and give \(\|P\|\le 1\). Haar invariance gives \(P^2=P\); inversion of \(h\) gives \(P^*=P\). Translating the averaging variable shows that its image is fixed by each \(R_h\), while averaging a fixed vector leaves it unchanged. These are Hilbert-space equalities; no common pointwise representative for all group elements is required. By Theorem [fdip-0080], \(T\) commutes with \(P\). Its restriction is therefore positive and trace class, and \(\langle f,Tf\rangle >0\) for nonzero physical \(f\) proves injectivity there. Set \(S=PT=PTP\) on the full link space. It acts as \(T_{\mathrm {phys}}\) on the physical space and as zero on its orthogonal complement, so \(S^N=PT^N\) has the asserted physical trace.
Averaging the first variable of the kernel of \(T\) gives the continuous kernel of \(S\): \[L(U,U')=b(U)b(U')\int _K \prod _e k(U_eh_{s(e)}U_e'^{-1}h_{t(e)}^{-1})\,dh.\] To obtain this expression, use invariance of \(b\) and move \(h_{t(e)}^{-1}\) from the front of the kernel argument to its end by centrality. Every factor is strictly positive.
The diagonal trace formula, including the case \(N=1\), can be justified directly. The rank-one expansion in Theorem [fdip-0080] gives \[S=\sum _I\alpha _I |P(b\phi _I)\rangle \langle P(b\phi _I)|\] in trace norm. Its kernel expansion converges uniformly when summed over finite sets of representation blocks. For one edge, unitarity gives \[\sum _{i,j}|\phi _{\rho ij}(U)|^2=d_\rho ^2.\] For the finite edge product, the diagonal sum over a tail of blocks is therefore the corresponding tail of \(\sum _I\alpha _I=\kappa ^{|E_s|}\), uniformly in \(U\). Cauchy–Schwarz gives the same bound off the diagonal. Multiplying by \(b\) and averaging in both variables preserve uniform convergence. Integrating the diagonal term by term consequently gives \[\int _XL(U,U)\,dU =\sum _I\alpha _I\|P(b\phi _I)\|_2^2 =\operatorname {Tr}S.\] Multiplication by a bounded function permits the same argument for \(\operatorname {Tr}(M_fS)\).
For \(N\ge 2\), the Hilbert–Schmidt kernel trace identity of Theorem [fdip-007V] gives \[\operatorname {Tr}(M_{f_0}S\cdots M_{f_{N-1}}S) =\int _{X^N}\prod _j f_j(U_j)L(U_j,U_{j+1})\,dU.\] All kernels are bounded on compact spaces, so repeated integrals are absolutely convergent. The same formula for \(N=1\) was proved by the diagonal expansion. Gauge-invariant multiplication commutes with \(P\); hence this full-space trace equals the physical-space trace in the statement. Expanding each \(L\) with an independent \(h_j\) gives \(\mathcal W_N\), because the two adjacent factors \(b(U_j)\) combine to \(e^{-V(U_j)}\). Taking every \(f_j=1\) proves the partition function; general \(f_j\) prove the expectation identity. Strict positivity and compactness of the weight give \(0<Z_N<\infty \). The displayed gauge transformation conjugates \(B_{j,e}\) by direct cancellation, which proves the final invariance assertion.
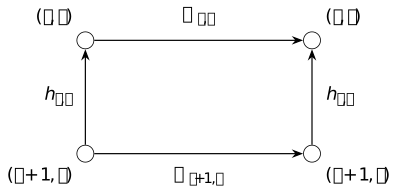
The temporal plaquette based at \((j,t)\) is traversed down the right edge, backwards along the bottom, up the left edge and then along the top. With the transport order, the first transport acts on the right and the product is exactly \(B_{j,e}\). Temporal averaging is retained at every step, so no periodic gauge-fixing assumption removes \(P\).
Example. Why the periodic trace needs gauge projection [fdip-0084]AGENTDRAFTED
- November 1, 2026
Example. Why the periodic trace needs gauge projection [fdip-0084]AGENTDRAFTED
- November 1, 2026
Take a graph with one edge and two distinct vertices, with \(G=\mathbb Z_2\), \(V=0\) and the sign kernel \(k(u)=e^{\beta u}\), \(\beta >0\). The link space has orthonormal basis \(1,u\), with \[T1=(\cosh \beta )1,\qquad Tu=(\sinh \beta )u.\] The two endpoint gauge transformations act by \(u\mapsto h_tuh_s\). Their action is transitive on the two link configurations. Thus the gauge projector satisfies \(P1=1\) and \(Pu=0\), and the physical space consists exactly of constants.
For every \(N\ge 1\), the projected and unprojected traces are \[\begin {aligned} \operatorname {Tr}(PT^N)&=(\cosh \beta )^N,\\ \operatorname {Tr}(T^N)&=(\cosh \beta )^N+(\sinh \beta )^N. \end {aligned}\] They are different because \(\beta >0\). In the temporal-link integral, each independent endpoint average gives \[\frac 14\sum _{h_s,h_t=\pm 1} e^{\beta U h_sU'h_t}=\cosh \beta .\] The remaining normalized link integrals contribute one, reproducing the projected answer. Dropping \(P\) would retain the nonphysical sign mode and change this finite periodic law.
Corollary. The physical spectral Hamiltonian [fdip-0085]AGENTDRAFTED
- November 1, 2026
Corollary. The physical spectral Hamiltonian [fdip-0085]AGENTDRAFTED
- November 1, 2026
For the physical transfer operator, let \(\lambda _0=\|T_{\mathrm {phys}}\|>0\) and fix a time step \(a_t>0\). There is an orthonormal eigenbasis \((\psi _j)\) with \(0<\lambda _j\le \lambda _0\), including an eigenvector at \(\lambda _0\). Define \[\widehat T=\frac {T_{\mathrm {phys}}}{\lambda _0},\qquad E_j=\frac 1{a_t}\log \frac {\lambda _0}{\lambda _j}.\] The transfer Hamiltonian is \(H=-a_t^{-1}\log \widehat T\), with the explicit domain and action \[\begin {aligned} D(H)&=\left \{f=\sum _jc_j\psi _j: \sum _jE_j^2|c_j|^2<\infty \right \},\\ Hf&=\sum _jE_jc_j\psi _j. \end {aligned}\] It is nonnegative and self-adjoint, and \(e^{-a_tH}=\widehat T\). If the physical Hilbert space is infinite dimensional, \(H\) is unbounded. This assertion does not specify the multiplicity of its zero eigenspace.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The spectral theorem for compact self-adjoint operators applies to the positive trace-class operator of Theorem [fdip-0083]. Injectivity removes its zero eigenspace, so the positive eigenvectors form a complete orthonormal basis. Its nonzero norm is an eigenvalue. In the finite-dimensional case the list is finite; otherwise its eigenvalues tend to zero.
The eigenspace-density assertion is formalized by
ContinuousLinearMap.orthogonalComplement_iSup_eigenspaces_eq_bot:
for a compact symmetric operator on a complete real or complex
inner-product space, the span of all eigenspaces has zero orthogonal
complement. This reference supplies that spectral premise; the
logarithm, its domain and its core are addressed below.
Under the unitary coefficient map \(f\mapsto (c_j)\), the normalized transfer is multiplication by \(\lambda _j/\lambda _0\). Its spectral logarithm is therefore multiplication by the real nonnegative sequence \(E_j\) on the stated maximal domain. This diagonal operator is self-adjoint; finite coefficient truncations form a core. Exponentiating on the basis proves the transfer identity. If the list is infinite, \(\lambda _j\to 0\) implies \(E_j\to \infty \), proving unboundedness.
This is the same normalization and domain construction as the Gaussian oscillator, without its explicit eigenvalues. It supplies a Hamiltonian at finite spatial volume. A unique vacuum, limits in time or volume, and a continuum field theory are separate questions, not conclusions of this spectral construction.
Theorem. Link reflection as a trace square [fdip-0086]AGENTDRAFTED
- November 1, 2026
Theorem. Link reflection as a trace square [fdip-0086]AGENTDRAFTED
- November 1, 2026
Use the periodic gauge law with \(N=2m\), \(m\ge 1\). Reflect time by \(\theta (j)=1-j\) modulo \(2m\); the positive half is \(\{1,\ldots ,m\}\). As in the scalar definition, this is a link reflection: its cuts lie between times \(0,1\) and \(m,m+1\).
Let \(\mathcal A_+\) consist of finite linear combinations of functions \[F(U)=\prod _{j=1}^m f_j(U_j),\] where each \(f_j:X\to \mathbb C\) is bounded, measurable and gauge invariant. These form an algebra of spatial observables. For such a product, on \(\mathcal H_{\mathrm {phys}}\) define \[A_F=T_{\mathrm {phys}}^{1/2}M_{f_1}T_{\mathrm {phys}} M_{f_2}\cdots T_{\mathrm {phys}}M_{f_m} T_{\mathrm {phys}}^{1/2},\] where for \(m=1\) this means \(T_{\mathrm {phys}}^{1/2}M_{f_1}T_{\mathrm {phys}}^{1/2}\). Extend this assignment linearly to finite sums. Then \(A_F\) is Hilbert–Schmidt and \[\mathbb E_{2m}\left [\overline {F(\theta U)}F(U)\right ] =\frac {\operatorname {Tr}(A_F^*A_F)}{Z_{2m}}\ge 0, \qquad (\theta U)_j=U_{1-j}.\] The temporal links have already been integrated in the periodic trace identity. No assertion about arbitrary observables involving individual temporal links is included.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The positive trace-class operator \(T_{\mathrm {phys}}\) has a Hilbert–Schmidt square root. Every multiplication operator here is bounded, as are all intervening transfer factors, so \(A_F\) is Hilbert–Schmidt; the same holds for a finite sum.
For products \(F=\prod _j f_j(U_j)\) and \(G=\prod _j g_j(U_j)\), the adjoint reverses the order and conjugates each multiplier. The bounded trace formula and cyclicity of a trace-class product give \[\operatorname {Tr}(A_F^*A_G) =Z_{2m}\,\mathbb E_{2m} \left [\overline {F(\theta U)}G(U)\right ].\] The cyclic order of the multipliers is \[\overline f_m,\ldots ,\overline f_1,g_1,\ldots ,g_m,\] with one full transfer between adjacent entries. They occur at times \(m+1,\ldots ,2m,1,\ldots ,m\), where \(2m=0\); hence \(f_j\) is conjugated at time \(1-j\). There are exactly \(2m\) transfer factors after the adjacent half-powers combine.
Expanding finite sums proves the same sesquilinear identity for all \(F,G\in \mathcal A_+\). If two product-sum presentations define the same function, their difference has zero expectation against its reflected conjugate, and the identity makes the corresponding difference of operators have Hilbert–Schmidt norm zero. Thus \(A_F\) is independent of that presentation. Taking \(G=F\) proves the trace-square identity and positivity.
This proof uses the explicitly positive operator of Theorem [fdip-0080] and the exact finite-time law of Theorem [fdip-0083]. It does not reverse the argument to reconstruct a transfer operator from an arbitrary reflection-positive law; the scalar quotient obstruction shows why that distinction matters.
Remark. The scope of the finite gauge construction [fdip-0087]AGENTDRAFTED
- November 1, 2026
Remark. The scope of the finite gauge construction [fdip-0087]AGENTDRAFTED
- November 1, 2026
The positive convolution theorem and projected finite-time trace law concern a specified pure-gauge model on a finite spatial graph. Their assumptions are the strictly positive, summable character coefficients of Definition [fdip-007Z], not reflection positivity alone. The trace-square theorem applies to the stated algebra of bounded gauge-invariant spatial observables.
Lüscher's construction includes \(SU(N)\) gauge fields and Wilson fermions. Proposition 1 proves self-adjointness, boundedness, gauge invariance and strict positivity of its transfer operator. Its factorization and argument using tensor characters motivate the pure-gauge proof here. The fermion factors require the stated hopping assumptions, including \(0<K_{\mathrm {hop}}<1/6\); \(K_{\mathrm {hop}}\) is that paper's hopping parameter, not the spatial gauge group \(K\) used here. See [luscher1977transfer, pp. 286–288, Proposition 1].
Proposition 2 in [luscher1977transfer, p. 289] identifies time-ordered expectations under its specified gauge fixing and boundary conditions: periodic gauge fields and anticyclic fermions in time. The qualification on periodic temporal gauge appears in footnote 3 on p. 285. The direct projected integral of Theorem [fdip-0083] retains temporal averaging, rather than using that gauge-fixing identification as a finite-periodic premise.
The spectral Hamiltonian has its stated maximal domain; boundedness of the transfer operator does not make its logarithm bounded. No unique-vacuum or continuum reconstruction claim is required. In particular, the joint Gaussian matter law and lattice fermion operators need their own transfer and positivity hypotheses.
Gauss's law and charged multiplicities [fdip-0088]AGENTDRAFTED
- November 1, 2026
Gauss's law and charged multiplicities [fdip-0088]AGENTDRAFTED
- November 1, 2026
The gauge transfer operator acts on all spatial link fields, while its physical trace uses gauge-invariant states. Temporal gauge explains the residual symmetry behind this constraint. With external charges, invariance applies to the link field together with its charge factors; it does not select a whole isotypic component of the link space.
The neutral projector is normalized averaging. Charged invariant tensors instead identify with a space of intertwiners. A single permutation-group link distinguishes a four-dimensional isotypic component from a one-dimensional charged space. A two-by-two sign lattice then counts neutral states by its gauge orbits. All graphs and time intervals here are finite.
Definition. Temporal gauge and the residual spatial action [fdip-0089]AGENTDRAFTED
- November 1, 2026
Definition. Temporal gauge and the residual spatial action [fdip-0089]AGENTDRAFTED
- November 1, 2026
Use the spatial graph and link space \(X=G^{E_s}\) and \(\mathcal H_{\mathrm {link}}=L^2(X,dU;\mathbb C)\). On a finite open time interval with slices \(0,\ldots ,N\), the temporal link \(h_{j,v}\) transports from \(j+1\) to \(j\) at spatial vertex \(v\). Allow independent gauge changes at all slices. For slice gauge changes \(g_j\in K\), where \(K=G^{V_s}\), it transforms as \[h_{j,v}\longmapsto g_{j,v}h_{j,v}g_{j+1,v}^{-1}.\] Temporal gauge means \(h_{j,v}=1\) on these temporal edges. Choose \(g_{0,v}\) and recursively set \(g_{j+1,v}=g_{j,v}h_{j,v}\) to reach this gauge.
A transformation preserving temporal gauge satisfies \(g_{j+1,v}=g_{j,v}\). Its remaining freedom is one spatial gauge transformation \(g\in K\), independent of time. This is the residual gauge action: \[(g\cdot U)_e=g_{t(e)}U_eg_{s(e)}^{-1},\qquad (R_gf)(U)=f(g^{-1}\cdot U).\] These are the same unitary operators used in the transfer construction, now interpreted on a time slice.
On a periodic time circle, the closure \(g_{N,v}=g_{0,v}\) changes the conclusion. The ordered temporal holonomy is \[H_v=h_{0,v}h_{1,v}\cdots h_{N-1,v}.\] The recursion closes exactly when \(H_v=1\). In general one can set the first \(N-1\) temporal links to one, but the last becomes \(g_{0,v}H_vg_{0,v}^{-1}\). Thus an arbitrary periodic field does not admit a gauge with every temporal link equal to one. The projected periodic trace keeps its temporal averaging and does not require such a gauge.
Kogut and Susskind's 1975 Hamiltonian formulation of Wilson's lattice gauge theories [kogut1975hamiltonian] provides historical context for this subject. The finite residual action above follows directly from the displayed transformation law; the state constraints below are established by averaging and representation theory.
Theorem. Neutral Gauss's law as an averaging constraint [fdip-008A]AGENTDRAFTED
- November 1, 2026
Theorem. Neutral Gauss's law as an averaging constraint [fdip-008A]AGENTDRAFTED
- November 1, 2026
For the residual action, the neutral Gauss constraint requires \[R_gf=f\qquad \text {for every }g\in K.\] Its solution space is the physical Hilbert space \(\mathcal H_{\mathrm {phys}}=\mathcal H_{\mathrm {link}}^K\). The orthogonal projector onto it is \[P=\int _KR_g\,dg,\] with normalized Haar measure. For a finite group \(G\), this is \[P=\frac 1{|G|^{|V_s|}}\sum _{g\in G^{V_s}}R_g.\] For the positive gauge transfer operator, \(TP=PT\); hence time evolution preserves the constraint.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For finite \(G\), left translation permutes the sum, so \(R_hPf=Pf\) for every \(h\). If \(f\) is invariant, every summand is \(f\), so \(Pf=f\). These facts prove \(P^2=P\) and identify its image. Unitarity gives \(R_g^*=R_{g^{-1}}\); inversion permutes the sum, proving \(P^*=P\). Thus \(P\) is the orthogonal projector.
For compact \(G\), the same identities use normalized Haar invariance, inversion and Fubini. The integral on \(L^2\), its boundedness and its image were proved in Theorem [fdip-0083]; that theorem applies here without a finite-group assumption. The transfer operator commutes with every \(R_g\) by Theorem [fdip-0080], so it commutes with the average.
The finite algebraic projection statement is
Representation.isProj_averageMap. It assumes an
invertible group order in the coefficient ring, as holds over
\(\mathbb C\). Unitarity gives the orthogonality used here;
the compact Haar and transfer assertions have the separate proofs
just cited. Maschke averaging uses a related finite
average to produce invariant complements.
For a finite configuration set \(X\), an invariant function is exactly a function constant on each gauge orbit. Consequently \[\dim _{\mathbb C}\mathcal H_{\mathrm {phys}}=|X/K|.\] Indeed, the orbit indicators have disjoint support and form a basis. For Haar probability on a finite set, dividing each indicator by the square root of its orbit's probability makes this basis orthonormal.
Theorem. Charged invariant tensors and multiplicity spaces [fdip-008B]AGENTDRAFTED
- November 1, 2026
Theorem. Charged invariant tensors and multiplicity spaces [fdip-008B]AGENTDRAFTED
- November 1, 2026
Let \((R,\rho )\) be a specified finite-dimensional continuous unitary representation of the residual group \(K\) over \(\mathbb C\). Its complex linear dual \(R^*\) carries \((\rho ^*(g)\lambda )(v)=\lambda (\rho (g)^{-1}v)\). The charged physical space for this charge datum is \[\mathcal H_{\mathrm {phys}}(R) =(\mathcal H_{\mathrm {link}}\otimes R^*)^K,\] where \(g\) acts as \(R_g\otimes \rho ^*(g)\). Since \(R\) is finite dimensional, the Hilbert tensor product here is a finite orthogonal sum of copies of \(\mathcal H_{\mathrm {link}}\).
There is a canonical unitary identification \[\mathcal H_{\mathrm {phys}}(R) \cong \operatorname {Hom}_K(R,\mathcal H_{\mathrm {link}}) =:\mathcal M_R.\] Here \(\operatorname {Hom}_K\) consists of the linear maps \(F\) satisfying \(R_gF=F\rho (g)\) for every \(g\); its inner product is \(\langle F,G\rangle _{\mathrm {HS}}=\operatorname {Tr}(F^*G)\), linear in the second argument. The transfer operator \(T\otimes I\) preserves charged physical states and corresponds to \(F\mapsto TF\).
Suppose further that \(R\) is irreducible and put \(d=\dim R\). Its isotypic component in this complex Hilbert setting is \(\mathcal H_R\), defined as the closed span of all images \(F(R)\) with \(F\in \mathcal M_R\). Then \[\begin {aligned} R\otimes \mathcal M_R&\longrightarrow \mathcal H_R,\\ v\otimes F&\longmapsto \sqrt d\,F(v) \end {aligned}\] is a unitary representation isomorphism, with trivial \(K\)-action on \(\mathcal M_R\). The charged physical space is \(\mathcal M_R\), whereas \(\mathcal H_R\) includes the additional factor \(R\). In finite dimension, their dimensions are respectively \(\dim \mathcal M_R\) and \(d\dim \mathcal M_R\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For an elementary tensor define \[\Phi (x\otimes \lambda )(v)=\lambda (v)x.\] If \(e_1,\ldots ,e_d\) is an orthonormal basis of \(R\) with dual basis \(e_1^*,\ldots ,e_d^*\), the inverse is \[F\longmapsto \sum _{i=1}^dF(e_i)\otimes e_i^*.\] Evaluating on the basis proves both inverse identities. The map \(\Phi \) is basis independent, so its inverse is as well. Its norm is the Hilbert–Schmidt norm \(\|F\|_{\mathrm {HS}}^2=\sum _i\|F(e_i)\|^2\), proving that \(\Phi \) is unitary.
Under \(\Phi \), the tensor action becomes \[F\longmapsto R_gF\rho (g)^{-1}.\] Indeed, apply both sides to \(v\) on an elementary tensor. Its fixed points are exactly the intertwiners, which proves the charged identification. The invariant subspace is closed, so \(\mathcal M_R\) is a Hilbert space. Since \(TR_g=R_gT\), postcomposition by \(T\) preserves intertwiners and corresponds to \(T\otimes I\).
For irreducible \(R\), unitarity and the intertwining identities show that \(F^*G:R\to R\) commutes with \(\rho (K)\). Complex Schur's lemma gives \[F^*G=\frac {\operatorname {Tr}(F^*G)}d I_R =\frac {\langle F,G\rangle _{\mathrm {HS}}}d I_R.\] One elementary proof of the lemma chooses an eigenvalue of a commuting complex endomorphism: its nonzero invariant eigenspace must be all of an irreducible representation. Therefore \[\langle F(v),G(w)\rangle =\frac 1d\langle v,w\rangle \langle F,G\rangle _{\mathrm {HS}}.\] Extending by linearity in finite sums proves that \(\sqrt d\) times evaluation is isometric. Its range is closed, and contains every \(F(R)\); by the definition of \(\mathcal H_R\), it is onto. The intertwining identity makes it equivariant. This proves the stated isotypic factorization and its normalization.
The algebraic tensor-to-map equivalence is formalized by
Representation.Equiv.dualTensorHom: its source order is
\(R^*\otimes \mathcal H_{\mathrm {link}}\), so first swap our two
factors. It requires finite-dimensional \(R\), with no dimension
restriction on \(\mathcal H_{\mathrm {link}}\).
The fixed-map step is formalized by
Representation.invariantsEquivIntertwiningMap for the
conjugation action on linear maps. The Hilbert–Schmidt isometry and
\(\sqrt d\) normalization are the direct arguments above. The earlier
real isotypic projectors and
multiplicity matrices concern whole representation
components; a projector onto such a component does not by itself
impose the charged tensor constraint.
For reducible charge data, first choose an irreducible orthogonal decomposition \(R=\bigoplus _\lambda R_\lambda \otimes \mathbb C^{n_\lambda }\). Applying the intertwiner identification to each summand gives \[\mathcal M_R\cong \bigoplus _\lambda \operatorname {Hom}(\mathbb C^{n_\lambda },\mathcal M_{R_\lambda }).\] This is an isomorphism of vector spaces. If all these spaces are finite dimensional and \(m_\lambda =\dim \mathcal M_{R_\lambda }\), then \(\dim \mathcal M_R=\sum _\lambda n_\lambda m_\lambda \). For the trivial one-dimensional charge, the construction recovers the neutral space.
Example. One permutation-group link has four isotypic states but one charged state [fdip-008C]AGENTDRAFTED
- November 1, 2026
Example. One permutation-group link has four isotypic states but one charged state [fdip-008C]AGENTDRAFTED
- November 1, 2026
Take one oriented edge with distinct source and target and \(G=S_3\). Then \(\mathcal H_{\mathrm {link}}=L^2(S_3)\) has complex dimension \(6\). Order the gauge factors as \(K=S_3^{\mathrm {target}}\times S_3^{\mathrm {source}}\); their function action is \[(R_{(h_t,h_s)}f)(U)=f(h_t^{-1}Uh_s).\] Let \(V=\{(z_1,z_2,z_3)\in \mathbb C^3:z_1+z_2+z_3=0\}\) carry the standard unitary permutation representation \(\rho \). Use the charge datum \[R=V_{\mathrm {target}}\otimes V_{\mathrm {source}}^*.\] It has dimension \(4\).
The standard representation is irreducible: a three-cycle has two distinct eigenlines on \(V\), with eigenvalues \(e^{2\pi i/3}\) and \(e^{-2\pi i/3}\), and a transposition exchanges them. Thus neither line is invariant under \(S_3\). The external tensor product \(R\) is also irreducible under \(K\). To see this, expand an endomorphism in a basis of \(\operatorname {End}(V^*)\). Commutation with the first factor and Schur's lemma make it \(I\otimes B\); commutation with the second factor makes \(B\) scalar. Any invariant subspace has a commuting orthogonal projector, so it is zero or all of \(R\).
The inverse matrix-coefficient map is \[\begin {aligned} \Psi :R&\longrightarrow L^2(S_3),\\ \Psi (v\otimes \lambda )(U) &=\sqrt 2\,\lambda (\rho (U^{-1})v). \end {aligned}\] Schur orthogonality makes this map isometric for normalized counting measure. Its order of duals is checked directly: \[R_{(h_t,h_s)}\Psi (v\otimes \lambda ) =\Psi (\rho (h_t)v\otimes \rho ^*(h_s)\lambda ).\] Thus its four-dimensional image is a copy of the specified charge representation, with the target and source conventions as stated.
The finite Peter–Weyl decomposition gives the bilateral decomposition \[L^2(S_3)\cong (\mathbf 1\otimes \mathbf 1) \oplus (\operatorname {sgn}\otimes \operatorname {sgn}) \oplus (V\otimes V^*).\] Indeed, the trivial, sign and standard representations are inequivalent, and their squared dimensions sum to \(1+1+4=6=|S_3|\), so their orthogonal coefficient spaces exhaust \(L^2(S_3)\). Hence the standard bilateral type has multiplicity one. By the charged-space theorem, \[\dim \mathcal H_R=4,\qquad \dim \mathcal H_{\mathrm {phys}}(R) =\dim \operatorname {Hom}_K(R,L^2(S_3))=1.\] The four-dimensional isotypic component is therefore not the charged physical space. Isotypic projectors separate representation types; invariant charge tensors supply the Gauss constraint.
Example. Thirty-two neutral states on a two-by-two sign torus [fdip-008D]AGENTDRAFTED
- November 1, 2026
Example. Thirty-two neutral states on a two-by-two sign torus [fdip-008D]AGENTDRAFTED
- November 1, 2026
Let the spatial vertices be \(V_s=(\mathbb Z/2\mathbb Z)^2\). For each vertex \(x\) and direction \(i\in \{1,2\}\), retain a separate edge \(e_{x,i}\) from \(x\) to \(x+\hat i\). There are 4 vertices and 8 indexed edges. In a period-two direction, \(e_{x,i}\) and \(e_{x+\hat i,i}\) have opposite endpoints but are distinct edges. The underlying graph is a multigraph with two parallel edges on each side of a square, not an ordinary four-cycle.
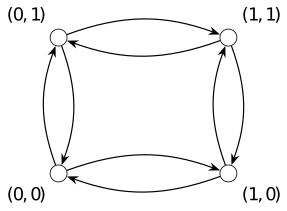
Each directed arc is one indexed edge. Horizontal and vertical arcs represent positive steps in the first and second coordinates, respectively; modulo two, both directions are positive coordinate steps. No face or plaquette constraint is imposed on the spatial link configurations in this example.
Take \(G=\mathbb Z_2\), written additively as \(\mathbb F_2\). A link configuration is \(u\in \mathbb F_2^{E_s}\), so \[\dim _{\mathbb C}\mathcal H_{\mathrm {link}}=2^8=256.\] A gauge function \(a\in \mathbb F_2^{V_s}\) acts by \[u_e\longmapsto u_e+a_{t(e)}+a_{s(e)}.\] The corresponding incidence map \(\delta :\mathbb F_2^{V_s}\to \mathbb F_2^{E_s}\) has kernel the constant functions: vanishing on every edge forces equal values along every path, and the graph is connected. Thus \(\dim \ker \delta =1\), \(\operatorname {rank}\delta =3\) and \(|\operatorname {im}\delta |=8\).
Every gauge orbit is a coset of \(\operatorname {im}\delta \), with 8 elements. The orbit basis therefore gives \[\dim _{\mathbb C}\mathcal H_{\mathrm {phys}} =\frac {256}{8}=32=2^5.\] The exponent is the cycle rank of this multigraph, \(b_1=|E_s|-|V_s|+1=8-4+1=5\). Equivalently, choose a spanning tree with three edges and set their additive link values to zero successively from a root. The remaining 5 chord values are free; the residual constant gauge function changes none of them. This supplies the same 32 representatives. The result counts neutral states of the link Hilbert space; it does not impose a flatness condition or identify opposite indexed edges.
Grassmann variables and finite fermion integrals [fdip-008E]AGENTDRAFTED
- November 1, 2026
Grassmann variables and finite fermion integrals [fdip-008E]AGENTDRAFTED
- November 1, 2026
Can electrons, which never share a state, be described in the probability-based setting? The spatial Dirac operator has a real matrix in its chosen basis and is skew-adjoint, so its real restriction satisfies \(D^T=-D\). For commuting real coordinates \(x\), transposition gives \(x^TDx=-x^TDx=0\). The weight \(e^{-x^TDx/2}\) is therefore constant, and adding a scalar mass leaves only \(m x^Tx\) in \(x^T(D+mI)x\): this quadratic expression loses the spatial operator.
Electrons are fermions: their multiparticle amplitudes change sign when two identical particles are exchanged [etingof2024mathematical, v2, Section 9.1, pp. 121-122]. Exclusion concerns the same complete one-particle state, including spin, not merely the same spatial orbital. The exterior algebra encodes the alternating sign through generators satisfying \(\psi _i\psi _j=-\psi _j\psi _i\) and \(\psi _i^2=0\) over \(\mathbb R\) or \(\mathbb C\). These are Grassmann variables. Their use here is an algebraic model of that sign rule, not a derivation of electron physics or a claim that measured fermion outcomes lack ordinary probabilities.
Integrating commuting Gaussian fields produces inverse powers of a determinant. For Grassmann variables, ordered top-coefficient extraction instead gives a determinant for independent paired variables and a Pfaffian for an alternating quadratic form. Two generators fix the signs before the general identities; the normalized Wick rule additionally requires invertibility. This algebraic integration is not a positive measure. Its relation to the earlier Clifford algebra is a vector-space comparison. Elimination, covariant lattice Dirac operators and their doubling problem are the later questions.
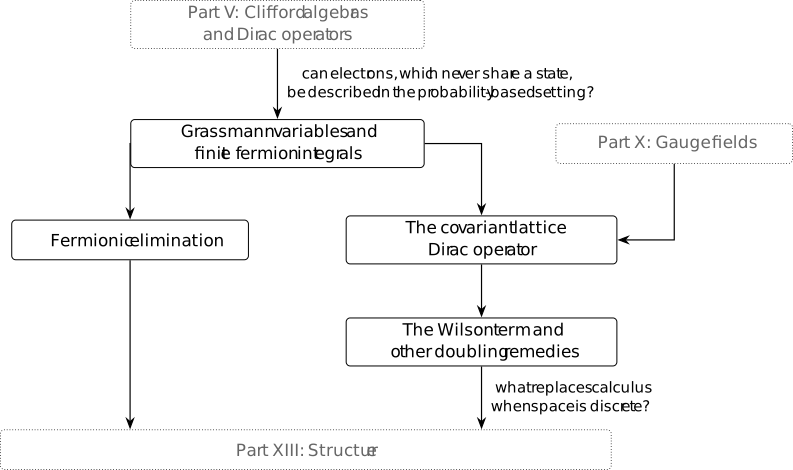
Definition. Ordered Berezin coefficients [fdip-008F]AGENTDRAFTED
- November 1, 2026
Definition. Ordered Berezin coefficients [fdip-008F]AGENTDRAFTED
- November 1, 2026
Let \(V\) be an \(N\)-dimensional vector space over \(\mathbb k=\mathbb R\) or \(\mathbb C\), with an ordered basis \(\xi _1,\ldots ,\xi _N\) of \(V^*\). The Grassmann algebra on these generators is the exterior algebra \(\Lambda (V^*)\). Multiplication is written by juxtaposition, so \[\xi _i\xi _j=-\xi _j\xi _i,\qquad \xi _i^2=0.\] Its basis consists of \(1\) and the increasing words \(\xi _{i_1}\cdots \xi _{i_r}\) with \(i_1<\cdots <i_r\); its dimension is \(2^N\). A word of length \(r\) has degree \(r\). Elements of even degree commute with every homogeneous element; two homogeneous elements of degrees \(r,s\) commute with sign \((-1)^{rs}\).
The Berezin integral with reversed top order is the linear functional \[I_\xi (f)=\text {coefficient of }\xi _N\cdots \xi _1 \text { in }f.\] Thus \(I_\xi (\xi _N\cdots \xi _1)=1\) and it vanishes on all lower degrees. Relative to the increasing top coefficient it has the sign \((-1)^{N(N-1)/2}\). For \(N=0\) it is the identity on \(\mathbb k\). This is the purely odd coefficient definition of [etingof2024mathematical, v2, Definition 9.6, p. 128], with the top order stated explicitly.
For \(n\) complex pairs, take \(2n\) independent generators \(\psi _1,\bar \psi _1,\ldots ,\psi _n,\bar \psi _n\) and use the paired functional \[J_n(f)=\text {coefficient of } \psi _1\bar \psi _1\cdots \psi _n\bar \psi _n \text { in }f.\] The bars label independent generators, not complex conjugates. The symbols \(I_\xi \) and \(J_n\) keep these two top-order conventions distinct. They are coefficient functionals, not positive measures on ordinary field configurations.
For a positive-degree nilpotent element \(q\), define
\(e^q=\sum _{r\ge 0}q^r/r!\); only finitely many terms survive.
For a quadratic \(q\) in \(N\) generators, terms with \(2r>N\)
vanish. No analytic convergence is involved. The ordered
monomial basis is supplied formally by
Module.Basis.ExteriorAlgebra; this supports the
algebraic coordinates, not the Berezin or Gaussian identities.
Example. Two generators fix the integration signs [fdip-008G]AGENTDRAFTED
- November 1, 2026
Example. Two generators fix the integration signs [fdip-008G]AGENTDRAFTED
- November 1, 2026
Take two generators and the alternating matrix \[A=\begin {pmatrix}0&a\\-a&0\end {pmatrix}.\] Anticommutation gives \[\tfrac 12\xi ^TA\xi =a\xi _1\xi _2.\] Since \((\xi _1\xi _2)^2=0\), \[e^{-\frac 12\xi ^TA\xi } =1-a\xi _1\xi _2=1+a\xi _2\xi _1.\] The reversed coefficient therefore gives \(I_\xi (e^{-\xi ^TA\xi/2})=a\). Selecting the increasing word \(\xi _1\xi _2\) instead would give \(-a\).
For one independent complex pair and any \(k\in \mathbb C\), \[e^{-k\bar \psi \psi }=1-k\bar \psi \psi =1+k\psi \bar \psi ,\qquad J_1(e^{-k\bar \psi \psi })=k.\] Both calculations use only the finite expansion and the ordered functionals in the definition, including when \(a=0\) or \(k=0\).
Theorem. Paired Grassmann integration gives a determinant [fdip-008H]AGENTDRAFTED
- November 1, 2026
Theorem. Paired Grassmann integration gives a determinant [fdip-008H]AGENTDRAFTED
- November 1, 2026
For any complex \(n\times n\) matrix \(K\), use the independent generators and paired top order. Then \[J_n\left (e^{-\bar \psi K\psi }\right )=\det K, \qquad \bar \psi K\psi =\sum _{i,j=1}^n\bar \psi _iK_{ij}\psi _j.\] No invertibility or positivity assumption is needed. The empty case has \(J_0(1)=1\), equal to the determinant of the empty matrix.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Move each barred generator to the right and put \[q_i=\sum _{j=1}^nK_{ij}\psi _j\bar \psi _i, \qquad -\bar \psi K\psi =\sum _iq_i.\] Each \(q_i^2=0\), because every term repeats \(\bar \psi _i\). The \(q_i\) have even degree and commute, so finite expansion gives \[e^{\sum _iq_i}=\prod _{i=1}^n(1+q_i).\] Only \(q_1\cdots q_n\) can contribute to the top degree. A nonzero term in that product chooses every unbarred generator once, hence is indexed by a permutation \(\sigma \in S_n\).
The associated word is \(\psi _{\sigma (1)}\bar \psi _1\cdots \psi _{\sigma (n)}\bar \psi _n\). Moving all barred factors to the right gives \((-1)^{n(n-1)/2}\). Sorting the unbarred factors gives \(\operatorname {sgn}(\sigma )\). Returning the bars to the paired top order gives the same first sign again. Their product is \(\operatorname {sgn}(\sigma )\). Thus the required coefficient is \[\sum _{\sigma \in S_n}\operatorname {sgn}(\sigma ) \prod _{i=1}^nK_{i,\sigma (i)}=\det K.\]
Selecting the grouped top word \(\psi _1\cdots \psi _n\bar \psi _1\cdots \bar \psi _n\) would instead give \((-1)^{n(n-1)/2}\det K\). There is a local ordering discrepancy in [etingof2024mathematical, v2, Proposition 9.10, p. 131]: the volume displayed immediately before the proposition is interleaved, whereas its printed determinant sign is the grouped one under Definition 9.6's coefficient rule. For \(n=2,K=I\), the exponential is \((1+\psi _1\bar \psi _1)(1+\psi _2\bar \psi _2)\); its interleaved coefficient is \(+1\) and its grouped coefficient is \(-1\). The direct expansion above fixes the convention used here.
Definition. The Pfaffian records signed pairings [fdip-008I]AGENTDRAFTED
- November 1, 2026
Definition. The Pfaffian records signed pairings [fdip-008I]AGENTDRAFTED
- November 1, 2026
Let \(A^T=-A\) be a \(2m\times 2m\) matrix over \(\mathbb R\) or \(\mathbb C\). A perfect matching of \(\{1,\ldots ,2m\}\) partitions it into pairs \((i_1,j_1),\ldots ,(i_m,j_m)\), written with \(i_r<j_r\) and \(i_1<\cdots <i_m\). Let \(\varepsilon (M)\) be the sign of the permutation with word \(i_1,j_1,\ldots ,i_m,j_m\). The Pfaffian is \[\operatorname {Pf}(A) =\sum _M\varepsilon (M)\prod _{r=1}^m A_{i_rj_r}.\] The empty Pfaffian is \(1\). This is the matching formula in [etingof2024mathematical, v2, Section 9.9, pp. 130-131].
Grouping matchings by the partner \(j\) of \(1\) gives \[\operatorname {Pf}(A)= \sum _{j=2}^{2m}(-1)^j A_{1j} \operatorname {Pf}(A_{\widehat 1\widehat j}),\] where the indicated two rows and columns are deleted, retaining the original order. Indeed, moving \(j\) immediately after \(1\) crosses \(j-2\) entries. In dimensions two and 4 this reads \[\operatorname {Pf}\begin {pmatrix}0&a\\-a&0\end {pmatrix}=a,\] \[\operatorname {Pf}(A)=A_{12}A_{34}-A_{13}A_{24}+A_{14}A_{23}.\] Each term pairs every index exactly once; unlike a determinant expansion, it sums over pairings rather than all permutations.
Theorem. An odd quadratic integral is a Pfaffian [fdip-008J]AGENTDRAFTED
- November 1, 2026
Theorem. An odd quadratic integral is a Pfaffian [fdip-008J]AGENTDRAFTED
- November 1, 2026
Let \(A^T=-A\) on \(2m\) generators and use the reversed top coefficient. Then \[I_\xi \left (e^{-\frac 12\xi ^TA\xi }\right ) =\operatorname {Pf}(A).\] This holds for singular as well as invertible \(A\). If \(A\) is invertible, then \(\operatorname {Pf}(A)\ne 0\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Put \(\Omega =\sum _{i<j}A_{ij}\xi _i\xi _j =\xi ^TA\xi/2\). In \(\Omega ^m\), a nonzero top word uses each generator exactly once. The even two-letter factors commute; every matching appears in \(m!\) orders. Reordering its word to \(\xi _1\cdots \xi _{2m}\) gives its matching sign. Therefore \[\frac {\Omega ^m}{m!} =\operatorname {Pf}(A)\xi _1\cdots \xi _{2m}.\] The top term of \(e^{-\Omega }\) is \((-1)^m\Omega ^m/m!\). Reversing \(2m\) generators has sign \((-1)^{m(2m-1)}=(-1)^m\); the two signs cancel. This proves the integral identity, without an inverse.
For the nonvanishing assertion, regard \(A\) as a nondegenerate alternating form on the vector space dual to the generators. Choose a nonzero \(u\) and then \(v\) with \(A(u,v)=1\). The plane they span is nondegenerate, and its orthogonal complement for \(A\) is a direct complement on which \(A\) remains nondegenerate. Induction gives a basis of such pairs. In the dual basis \(\alpha _1,\beta _1,\ldots ,\alpha _m,\beta _m\), \[\Omega =\sum _{r=1}^m\alpha _r\beta _r,\qquad \frac {\Omega ^m}{m!}=\alpha _1\beta _1\cdots \alpha _m\beta _m\ne 0.\] An invertible change of generators multiplies a top word by a nonzero determinant. The displayed top coefficient is therefore nonzero in the original basis as well, proving \(\operatorname {Pf}(A)\ne 0\). The zero-dimensional case is \(1\).
In [etingof2024mathematical, v2, Proposition 9.9, p. 131], the increasing top order accompanies a positive quadratic exponent. Replacing \(A\) by \(-A\) contributes \((-1)^m\) to the Pfaffian, and reversing the top order contributes the same sign. Thus the convention conversion agrees with the direct proof.
Theorem. The odd Wick rule pairs inverse alternating entries [fdip-008K]AGENTDRAFTED
- November 1, 2026
Theorem. The odd Wick rule pairs inverse alternating entries [fdip-008K]AGENTDRAFTED
- November 1, 2026
Let \(A^T=-A\) be an invertible \(2m\times 2m\) matrix. Its nonzero Pfaffian defines the normalized linear functional \[W_A(f)=\frac {I_\xi (f e^{-\xi ^TA\xi/2})} {\operatorname {Pf}(A)}.\] For linear Grassmann elements \(\lambda _a=\sum _i\ell _{ai}\xi _i\), put \(C_{ab}=\ell _aA^{-1}\ell _b^T\). For every \(r\ge 0\), \[W_A(\lambda _1\cdots \lambda _{2r})=\operatorname {Pf}(C),\] where \(C\) is the \(2r\times 2r\) alternating matrix just defined. Every odd product has value zero. Repeated or dependent \(\lambda _a\) are allowed. The inverse formula requires invertible \(A\); it asserts no singular extension.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Define the left derivative on a monomial by \[\partial _i(\xi _{j_1}\cdots \xi _{j_s}) =\sum _{a=1}^s(-1)^{a-1}\delta _{i,j_a} \xi _{j_1}\cdots \widehat {\xi _{j_a}}\cdots \xi _{j_s}.\] This respects the exterior relations. Splitting the removed positions between two factors gives the graded product rule \[\partial _i(fg)=(\partial _i f)g+(-1)^s f(\partial _i g)\] when \(f\) is homogeneous of degree \(s\). It lowers degree, so \(I_\xi (\partial _i h)=0\) for every \(h\).
Write \(E=e^{-\xi ^TA\xi/2}\). Differentiating its finite series, using that its quadratic exponent is even, gives \[\partial _iE=-\sum _jA_{ij}\xi _jE.\] For odd homogeneous \(f\), the product rule and coefficient of the total derivative imply \[\begin {aligned} 0&=I_\xi ((\partial _i f)E+f\sum _jA_{ij}\xi _jE),\\ \sum _jA_{ij}W_A(\xi _jf)&=W_A(\partial _i f). \end {aligned}\] The second line uses \(f\xi _j=-\xi _jf\). Multiplying by \(A^{-1}\) gives \[W_A(\xi _kf)=\sum _i(A^{-1})_{ki}W_A(\partial _i f).\]
Apply this to \(f=\lambda _2\cdots \lambda _{2r}\) and expand \(\lambda _1\). The derivative removes its \(a\)-th listed factor with sign \((-1)^{a-2}\), yielding \[\begin {aligned} W_A(\lambda _1\cdots \lambda _{2r}) &=\sum _{a=2}^{2r}(-1)^a C_{1a}\\ &\quad \cdot W_A(\lambda _2\cdots \widehat {\lambda _a} \cdots \lambda _{2r}). \end {aligned}\] Starting from \(W_A(1)=1\), this is exactly the Pfaffian recursion. Odd products have odd degree, while \(E\) has only even degrees and the selected top degree \(2m\) is even; hence their integrals vanish.
The left derivative is contraction by the coordinate functional
\(\xi _j\mapsto \delta _{ij}\). TauCeti's
TauCeti.ExteriorAlgebra.contractLeft_ιMulti
gives the alternating deletion formula. At zero quadratic form,
CliffordAlgebra.contractLeft_mul
gives the product rule: the grade involution acts by \((-1)^s\)
in degree \(s\). These support the contraction identities;
the Berezin normalization and Wick recurrence are the direct
argument above.
For \(A=\left (\begin {smallmatrix}0&a\\-a&0\end {smallmatrix}\right )\) with \(a\ne 0\), the two-generator calculation gives \(W_A(\xi _1\xi _2)=-1/a=(A^{-1})_{12}\). This checks the inverse-pairing sign. In [etingof2024mathematical, v2, Theorem 9.11, p. 132], the increasing top order gives normalization \(\operatorname {Pf}(-A)\). Changing the volume multiplies both numerator and normalization by the same sign, leaving this normalized Wick rule unchanged.
Remark. Exterior symbols preserve vectors, not Clifford products [fdip-008L]AGENTDRAFTED
- November 1, 2026
Remark. Exterior symbols preserve vectors, not Clifford products [fdip-008L]AGENTDRAFTED
- November 1, 2026
The Grassmann algebra and the earlier
configuration Clifford algebra share an exterior
vector-space model. For a quadratic form \(q\) on \(V^*\),
the symbol map is a linear isomorphism
\[\operatorname {Cl}(V^*,q)\cong \Lambda (V^*).\]
This is [meinrenken2013clifford, Proposition 2.5, pp. 32-33]
and the equivalence used in the
transported exterior-basis coordinates.
The formal declaration CliffordAlgebra.equivExterior
supplies a module equivalence over any commutative ring in which
\(2\) is invertible; it does not identify the products.
For example, an exterior generator satisfies \(\xi ^2=0\), while the corresponding Clifford generator satisfies \(\iota _q(\xi )^2=q(\xi )1\). For \(q(\xi )\ne 0\) these cannot be the same multiplication under a unit-preserving map. The quadratic form remains in Clifford contraction terms. The associated graded algebra forgets those lower terms, but the Clifford algebra itself does not. Therefore the Berezin functional and its determinant formulas belong to the exterior product; the vector-space comparison alone does not transfer them to a Clifford product.
Fermionic elimination [fdip-009I]AGENTDRAFTED
- November 1, 2026
Fermionic elimination [fdip-009I]AGENTDRAFTED
- November 1, 2026
What remains after some fermion variables are eliminated? The paired Grassmann integral replaces a Gaussian normalizer by a determinant, but the effective quadratic form is still a Schur complement. The eliminated block must be invertible; the full matrix need not be positive or invertible for this algebraic identity.
A commuting complex field supplies the inverse determinant when the Hermitian part of its matrix is positive. This is an ordinary convergent integral on twice as many real coordinates. Its cancellation with the Grassmann determinant uses the same matrix in both quadratic forms. A non-Hermitian accretive matrix usually gives a complex weight, so this cancellation does not construct a positive joint probability law.
The logarithm of the determinant needs an additional choice. On the accretive cone there is a unique analytic logarithm normalized at the identity; it need not be the principal scalar logarithm of the determinant. The four-cycle makes these distinctions concrete with the same effective matrix as in real Gaussian elimination.
Theorem. Partial Grassmann integration and the Schur complement [fdip-009J]AGENTDRAFTED
- November 1, 2026
Theorem. Partial Grassmann integration and the Schur complement [fdip-009J]AGENTDRAFTED
- November 1, 2026
Let \(R,U\) be disjoint ordered finite sets. Order the independent paired generators with all retained \(R\)-pairs first and all eliminated \(U\)-pairs second. For \(n=|R|+|U|\), let \[K=\begin {pmatrix}A&B\\C&D\end {pmatrix} \in M_n(\mathbb C).\] Require \(D=K_{UU}\) to be invertible and put \(S=A-BD^{-1}C\). No adjoint relation between \(B,C\) is assumed. Define \(J_U\) by taking the coefficient of the ordered \(U\)-pair top word after moving retained generators to the left. The result is an element of the retained exterior algebra. Define \(J_R\) by its paired top word, so \(J_RJ_U=J_n\). The eliminated top word has even degree, so moving it past a retained coefficient gives no further sign. Then \[J_U\left (e^{-\bar \psi K\psi }\right ) =\det D\,e^{-\bar \psi _R S\psi _R},\] and consequently \[\det K=\det D\det S.\] The empty-block conventions are determinant one and the identity coefficient map. Invertibility of \(K\) or \(S\) is unnecessary.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Introduce the odd linear combinations \[\begin {aligned} \chi _U&=\psi _U+D^{-1}C\psi _R,\\ \bar \chi _U&=\bar \psi _U+\bar \psi _RBD^{-1}. \end {aligned}\] The bars remain labels of independent generators. Expanding in the displayed multiplication order gives \[\bar \psi K\psi =\bar \psi _R S\psi _R+\bar \chi _U D\chi _U.\] For example, the last term of the expansion of \(\bar \chi _U D\chi _U\) is \(\bar \psi _RBD^{-1}C\psi _R\), which cancels the subtraction in \(S\). All these quadratic elements are even. They commute, so their finite exponentials multiply.
Replacing an eliminated generator by itself plus a retained odd linear combination preserves its partial top coefficient. Indeed, expand each exterior monomial in the new symbols: every term using a retained replacement has fewer eliminated generators, while the term using no replacement has coefficient one and its original order. Terms of lower eliminated degree cannot contribute to the top degree. Thus the coefficient in the shifted quadratic exponential equals the coefficient for independent \(U\)-generators. The paired determinant identity evaluates it as \(\det D\). The retained exponential factors on the left, proving the partial formula. Applying \(J_R\) and the same determinant identity proves the full factorization.
The effective matrix is the same block expression as in real positive Gaussian elimination. The scalar here is \(\det D\); the real Gaussian fiber integral instead has \((2\pi )^{|U|/2}(\det D)^{-1/2}\) under its real positive hypotheses and volume convention. Neither positivity nor an ordinary integration measure was used in the Grassmann proof.
The finite block identity is also supplied by
Matrix.det_fromBlocks₂₂, for finite index types over a
commutative ring with an invertible eliminated block. This
formal statement supports the determinant factorization, not
the partial Grassmann coefficient operation.
Theorem. Accretive complex Gaussian integrals and cancellation [fdip-009K]AGENTDRAFTED
- November 1, 2026
Theorem. Accretive complex Gaussian integrals and cancellation [fdip-009K]AGENTDRAFTED
- November 1, 2026
Call \(K\in M_n(\mathbb C)\) strictly accretive when its Hermitian part \(H=(K+K^*)/2\) is positive definite. For \(z_j=x_j+iy_j\), use ordinary Lebesgue volume \(d^{2n}z=\prod _j dx_j\,dy_j\). Then \(K\) is invertible, the following integral converges absolutely, and \[I(K):=\int _{\mathbb C^n}e^{-z^*Kz}\,d^{2n}z =\frac {\pi ^n}{\det K}.\] Consequently, with \(Z_B(K)=\pi ^{-n}I(K)\) and the paired Grassmann value \(Z_F(K)=J_n(e^{-\bar \psi K\psi })\), \[Z_B(K)Z_F(K)=1.\] For \(n=0\) both factors are one.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
For \(n>0\), choose \(h>0\) with \(H\ge hI\). Then \[|e^{-z^*Kz}|=e^{-z^*Hz}\le e^{-h\|z\|^2}.\] The right side is integrable by the product of scalar Gaussian integrals. If \(Kz=0\), its real quadratic value is \(z^*Hz=0\), so \(z=0\); finite dimension makes \(K\) invertible.
First suppose \(K=K^*>0\). A unitary eigenbasis gives positive eigenvalues \(\lambda _j\). The unitary change of variables preserves real volume, since its real Jacobian has absolute determinant \(|\det _{\mathbb C}U|^2=1\). In each complex coordinate the scalar Gaussian formula gives \[\int _{\mathbb R^2}e^{-\lambda _j(x^2+y^2)}dx\,dy =\frac \pi {\lambda _j}.\] Multiplication gives \(I(K)=\pi ^n/\det K\).
For general \(K\), write \(K=H+A\), where \(A^*=-A\), and set \(K(w)=H+wA\) for a complex parameter \(w\). Its Hermitian part is \(H+i(\operatorname {Im}w)A\). Choose \(\epsilon >0\) such that \(\epsilon \|A\|<h/2\), with any positive choice if \(A=0\). On the connected strip \(|\operatorname {Im}w|<\epsilon \), this part is at least \(hI/2\), so \(K(w)\) is invertible.
The integral \(I(K(w))\) is holomorphic on that strip. Differentiation of the integrand brings down powers of \(-z^*Az\); on every smaller neighborhood these are bounded by a polynomial in \(\|z\|\) times \(e^{-h\|z\|^2/2}\). This integrable bound justifies differentiation under the integral. The function \(\pi ^n/\det K(w)\) is holomorphic there too. For \(w=it\) with real \(|t|<\epsilon \), the matrix \(H+itA\) is Hermitian positive, so the preceding calculation identifies the two functions. These points accumulate at the interior point zero. The one-variable identity theorem therefore identifies the functions throughout the strip, in particular at \(w=1\). The Grassmann determinant then proves cancellation.
For Hermitian positive \(K\), the normalized density \((\det K/\pi ^n)e^{-z^*Kz}\) is a genuine Gaussian probability law on \(2n\) real coordinates. For general accretive \(K\), the weight can be complex: \(K=(1+i)\) gives \(Z_F=1+i\) and \(Z_B=(1+i)^{-1}\). Normalization and determinant cancellation still hold, but there is no positive Gaussian law with this density. A single real Gaussian has only a determinant power \(-1/2\); Grassmann algebra by itself supplies no convergence for a commuting integral.
Accretivity also survives the Schur operation. Its principal block \(D\) is accretive by testing \(K\) on \((0,u)\), hence invertible. For \(v\ne 0\), put \(x=(v,-D^{-1}Cv)\). Then \(Kx=(Sv,0)\), and \[\operatorname {Re}(v^*Sv) =\operatorname {Re}(x^*Kx)>0.\] Thus \(S\) is accretive. This extra conclusion uses accretivity of the full matrix, not just invertibility of \(D\).
[wingate2025lattice, Section 9.1, equations (9.3)-(9.5), p. 19] describes integrating a fermion matrix and re-expressing its determinant with commuting complex pseudofermions. Its equation (9.5) uses \(K^{-1}\) in the commuting quadratic form, yielding a determinant rather than its inverse when convergence holds. The cancellation here uses \(K\) in both forms and the specified factor \(\pi ^{-n}\); the proof above states its convergence hypotheses explicitly.
Proposition. The logarithm on the accretive cone [fdip-009L]AGENTDRAFTED
- November 1, 2026
Proposition. The logarithm on the accretive cone [fdip-009L]AGENTDRAFTED
- November 1, 2026
On the open convex cone \(\mathcal C_n\) of strictly accretive complex matrices, there is a unique holomorphic function \(\mathcal L\) such that \[e^{\mathcal L(K)}=\det K,\qquad \mathcal L(I)=0.\] For \(K_t=I+t(K-I)\), it is given by \[\mathcal L(K)=\int _0^1 \operatorname {tr}\left [K_t^{-1}(K-I)\right ]dt.\] On Hermitian positive matrices it equals the real \(\log \det K\). Thus the fermionic logarithmic contribution \(W_F(K)=-\mathcal L(K)\) is unambiguous on this cone.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Write \(K_t=I+t(K-I)\). Convexity makes \(K_t\) accretive and invertible for every \(0\le t\le 1\). In a neighborhood of each \(K\in \mathcal C_n\), the Hermitian parts of all these matrices have a common positive lower bound. Their inverses and derivatives in the matrix entries are therefore locally bounded uniformly in \(t\). The integral of the holomorphic rational integrand is holomorphic in \(K\).
Put \(g(t)=\det K_t\). The determinant derivative, as in the real log-determinant calculation, gives \[\frac {g'(t)}{g(t)} =\operatorname {tr}(K_t^{-1}(K-I)).\] This complex version follows directly from \(\det (K_t+hB)=\det K_t\det (I+hK_t^{-1}B)\) and \(\det (I+hM)=1+h\operatorname {tr}M+O(h^2)\), obtained by the permutation expansion. Therefore the derivative of \(g(t)\exp (-\int _0^t g'(s)/g(s)\,ds)\) is zero. Its value at zero is one, proving \(\exp \mathcal L(K)=\det K\); the identity matrix gives \(\mathcal L(I)=0\).
Two such logarithms differ by a continuous function with values in \(2\pi i\mathbb Z\). The cone is connected, so this function is constant, and normalization makes it zero. On Hermitian positive \(K\), all \(K_t\) are positive and \(g(t)>0\); ordinary real logarithmic differentiation identifies the integral with \(\log \det K\).
This branch is not always the principal scalar logarithm of \(\det K\). For \(K=e^{i\pi /3}I_4\), the Hermitian part is \(I_4/2>0\). Along \(K(s)=e^{is}I_4\), \(0\le s\le \pi /3\), continuity and normalization give \(\mathcal L(K(s))=4is\). Hence \[\mathcal L(e^{i\pi /3}I_4)=\frac {4\pi i}{3},\] whereas the principal scalar logarithm of its determinant is \(-2\pi i/3\). The determinant can even reach the scalar principal branch cut while the matrix stays accretive.
For a general invertible complex matrix, writing \(-\log \det K\) requires a declared branch on the domain under consideration; there is no single-valued continuous logarithm on all invertible matrices when \(n\ge 1\). The loop \(\operatorname {diag}(e^{it},1,\ldots ,1)\), \(0\le t\le 2\pi \), already has determinant winding once. If \(\det K=0\), no logarithm exists, although the Grassmann determinant identity still does. The boson-fermion cancellation itself uses no logarithm branch.
Example. The same four-cycle Schur matrix with fermions [fdip-009M]AGENTDRAFTED
- November 1, 2026
Example. The same four-cycle Schur matrix with fermions [fdip-009M]AGENTDRAFTED
- November 1, 2026
Take the alternating four-cycle with \(t,m>0\), set \(a=m^2\), \(s=1+t+a\), and use \(K=Q_{t,m}=L_t+aI\) now as a complex matrix. Order retained vertices \(R=(0,2)\) before eliminated vertices \(U=(1,3)\). Its blocks are \[A=D=sI_2,\qquad B=C=-\begin {pmatrix}1&t\\t&1\end {pmatrix}.\] The fermionic Schur formula gives \[J_U(e^{-\bar \psi K\psi }) =s^2e^{-\bar \psi _R S\psi _R},\] where \[\begin {aligned} S&=\begin {pmatrix}\alpha &-\beta \\-\beta &\alpha \end {pmatrix},\\ \alpha &=s-\frac {1+t^2}{s},\qquad \beta =\frac {2t}{s}. \end {aligned}\] This is exactly the real Gaussian effective precision. The fermionic scalar is \(s^2\); the real Gaussian eliminated factor in the cited example is \(2\pi /s\).
The two eigenvalues of \(S\) are \[\frac {a(a+2+2t)}s,\qquad \frac {(a+2)(a+2t)}s.\] Writing \(\mathcal D=a(a+2)(a+2t)(a+2+2t)\), it follows that \[\det S=\frac {\mathcal D}{s^2},\qquad Z_F(K)=s^2\det S=\mathcal D.\] Positivity of \(K\) also allows the ordinary complex integral with normalized volume \(\pi ^{-4}d^8z\). The complex Gaussian theorem gives \[Z_B(K)=\mathcal D^{-1},\qquad Z_F(K)Z_B(K)=1.\] In contrast, the original real Gaussian, with exponent \(-\phi ^TK\phi /2\) and volume \(d^4\phi \), has partition function \((2\pi )^2/\sqrt {\mathcal D}\). These powers and constants refer to different field spaces and measures.
At \(t=m=1\), \(s=3\), \(\mathcal D=45\), and \[S=\begin {pmatrix}7/3&-2/3\\-2/3&7/3\end {pmatrix}, \qquad \det S=5.\] The Grassmann eliminated factor \(9\) times the retained factor \(5\) gives \(45\), while the normalized complex-boson value is \(1/45\). At \(t=2,m=1\), \(s=4\), \(\det S=105/16\); the product is \(16\cdot 105/16=105\). These are the same two effective matrices compared in the weighted-cycle example.
At \(m=0,t>0\), the eliminated block \((1+t)I_2\) is still invertible and the partial Grassmann formula is valid. The retained Schur matrix has a constant zero mode, so \(\det K=0\): the full Grassmann integral vanishes. The commuting full Gaussian instead diverges in its constant mode. There is no finite inverse determinant, cancellation identity or logarithmic contribution at this massless point.
The covariant lattice Dirac operator [fdip-009N]AGENTDRAFTED
- November 1, 2026
The covariant lattice Dirac operator [fdip-009N]AGENTDRAFTED
- November 1, 2026
How does a fermion move through a fixed gauge connection? The spatial Dirac operator combines centered differences with Clifford matrices. The connection background compares fields at neighboring vertices by parallel transport. Combining them requires two separate factors: a Clifford module \(S\) and an internal representation \(F\). The gauge links act on \(F\), while the gamma matrices act on \(S\).
This separation makes the operator gauge covariant and skew-adjoint. It also identifies its finite matrix as a possible kernel for the paired Grassmann integral, without claiming a positive probability density. At the trivial connection, the Fourier blocks retain the centered difference's sine symbol. Their exact zero modes depend on the parity of the finite periods; the extra local branches of the continuous momentum symbol are a different count. Fixed antiperiodic boundary conditions change the sampling but do not remove those branches.
A group acting on spin frames has a different role from an internal gauge group. Even when both are described using \(SU(2)\) or a binary rotation group, their actions and the Clifford compatibility must be supplied separately.
Definition. Covariant centered differences with an internal fiber [fdip-009O]AGENTDRAFTED
- November 1, 2026
Definition. Covariant centered differences with an internal fiber [fdip-009O]AGENTDRAFTED
- November 1, 2026
Use the periodic grid and Clifford module: \(d\ge 1\), periods \(N_j\ge 3\), \(\Lambda =\prod _j\mathbb Z/N_j\mathbb Z\), and \(S=(\mathbb C^2)^{\otimes d}\) with Hermitian matrices \(\gamma _j\). Thus \(\dim _{\mathbb C}S=2^d\) and \[\gamma _i\gamma _j+\gamma _j\gamma _i=2\delta _{ij}I_S.\] The lattice spacing is one. Choose a nonzero finite-dimensional complex Hermitian space \(F\), with \(q=\dim _{\mathbb C}F\), and a unitary representation \(\rho :G\to U(F)\) of a finite or compact group, continuous in the compact case. The invariant metric is part of the representation datum. The field space is \[\mathcal H=\ell ^2(\Lambda )\otimes S\otimes F,\] identified with maps \(\psi :\Lambda \to S\otimes F\), with \[\langle \psi ,\phi \rangle =\sum _{x\in \Lambda }\langle \psi (x),\phi (x)\rangle _{S\otimes F}.\] Dimensions are over \(\mathbb C\); adjoints use the declared Hermitian inner products.
Assign \(U_j(x)\in G\) to the oriented edge \(x\to x+e_j\), and also write \(U_j(x)\) for its unitary action \(\rho (U_j(x))\) on \(F\). The source-to-head convention means that comparing a value at \(x+e_j\) with one at \(x\) uses the inverse transport. Define \[\begin {gathered} (T_j^U\psi )(x) = (I_S\otimes U_j(x)^{-1})\psi (x+e_j),\\ ((T_j^U)^{-1}\psi )(x)\\ = (I_S\otimes U_j(x-e_j))\psi (x-e_j). \end {gathered}\] Substitution verifies that the second operator is the inverse of the first. Put \[\nabla _j^U=\frac {T_j^U-(T_j^U)^{-1}}2,\qquad \Gamma _j=\gamma _j\otimes I_F,\] where \(\Gamma _j\) acts pointwise on the field. The covariant lattice Dirac operator is \[D_U=\sum _{j=1}^d\Gamma _j\nabla _j^U.\] This is the centered nearest-neighbor convention in [wingate2025lattice, Section 9.1, Equations (9.1)–(9.2), p. 19], with spacing one and the declared link orientation.
For \(g:\Lambda \to G\), write \(g_x=\rho (g(x))\) in operator formulas. The transformed links and field are \[\begin {aligned} U_j^g(x)&=g_{x+e_j}U_j(x)g_x^{-1},\\ (\mathcal G\psi )(x)&=(I_S\otimes g_x)\psi (x). \end {aligned}\] This is an internal gauge transformation: it fixes the lattice and the chosen Clifford matrices. Links and \(\mathcal G\) commute with every \(\Gamma _j\), because they act on the other tensor factor.
Theorem. Gauge covariance and skew-adjointness of the Dirac operator [fdip-009P]AGENTDRAFTED
- November 1, 2026
Theorem. Gauge covariance and skew-adjointness of the Dirac operator [fdip-009P]AGENTDRAFTED
- November 1, 2026
For the declared unitary internal connection, \[\begin {aligned} (T_j^U)^*&=(T_j^U)^{-1},\\ D_U^*&=-D_U,\\ D_{U^g}\mathcal G&=\mathcal G D_U. \end {aligned}\] Consequently the spectrum and determinant of \(D_U\), and of \(mI+D_U\) for a fixed scalar \(m\), are gauge invariant.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The operator \(T_j^U\) is the product of pointwise unitary multiplication by \(I_S\otimes U_j(x)^{-1}\) and the periodic forward shift. Reindexing the counting inner product shows that the shift is unitary, as in Definition [fdip-000R]. Their product is therefore unitary, with the inverse already displayed in the definition. Thus \((\nabla _j^U)^*=-\nabla _j^U\). Since \(\Gamma _j^*=\Gamma _j\) and \(\Gamma _j\) commutes with \(\nabla _j^U\), the adjoint of their product is its negative. Summing proves the second identity.
The transformed inverse link is \[U_j^g(x)^{-1}=g_xU_j(x)^{-1}g_{x+e_j}^{-1}.\] Therefore \[\begin {aligned} (T_j^{U^g}\mathcal G\psi )(x) &=(I_S\otimes g_xU_j(x)^{-1})\psi (x+e_j)\\ &=(\mathcal G T_j^U\psi )(x). \end {aligned}\] Both shifts are invertible, so the same intertwining identity holds for their inverses and hence their centered differences. Commutation of \(\mathcal G\) with each \(\Gamma _j\) then gives \(D_{U^g}\mathcal G=\mathcal G D_U\). The operator \(\mathcal G\) is unitary and invertible. The two Dirac matrices are conjugate, as are their scalar translates, proving the spectral and determinant statements.
For a general connection, the coordinate shifts need not commute. Accordingly the free identity \(D^2=\sum _j\nabla _j^2\) cannot be imported without its commutation hypothesis. In the present notation direct expansion gives \[\begin {aligned} D_U^2&=\sum _j(\nabla _j^U)^2\\ &\quad +\sum _{i<j}\Gamma _i\Gamma _j [\nabla _i^U,\nabla _j^U], \end {aligned}\] where \([A,B]=AB-BA\). The first sum includes the identity on \(S\); the second sum need not vanish. Skew-adjointness still implies \(D_U^*D_U=-D_U^2\ge 0\). This does not identify that square with the nearest-neighbor connection Laplacian.
The formal adjoint identities linked in the free square theorem support the algebraic ingredients; the shifted-link reindexing and the internal-factor commutation are the explicit calculations here. In any chosen orthonormal basis of \(\mathcal H\), the paired Grassmann formula applies to \(mI+D_U\) as a finite complex matrix. This observation requires neither positivity nor invertibility and is not an ordinary probability interpretation.
Theorem. Free and antiperiodic Dirac kernels with internal multiplicity [fdip-009Q]AGENTDRAFTED
- November 1, 2026
Theorem. Free and antiperiodic Dirac kernels with internal multiplicity [fdip-009Q]AGENTDRAFTED
- November 1, 2026
For the covariant Dirac data, take the trivial connection \(U_j(x)=I_F\) and write \(D_0\) for its operator. If \(e\) is the number of even periods, then \[\dim _{\mathbb C}\ker D_0=q\,2^{d+e}.\] There are exactly \(2^e\) zero momentum blocks, each of dimension \(q\,2^d\). If instead every coordinate has the fixed scalar antiperiodic boundary condition, the corresponding operator \(D^-\) satisfies \[\dim _{\mathbb C}\ker D^- =\begin {cases} q\,2^d,&\text {all }N_j\text { are odd},\\ 0,&\text {some }N_j\text { is even}. \end {cases}\] The antiperiodic statement applies to the specified scalar boundary condition on \(S\otimes F\). Interpreting its seam transport as a \(G\)-connection requires \(-I_F\in \rho (G)\); otherwise it is an external scalar twist, or can be supplied by an additional \(\mathbb Z_2\) factor.
Proof.
- November 1, 2026
Proof.
- November 1, 2026
Tensor the complete normalized finite Fourier basis with \(S\otimes F\). For \(p_j=2\pi r_j/N_j\), \(0\le r_j<N_j\), the block is \[\begin {aligned} D_0(p)&=i\sum _j\Gamma _j\sin p_j,\\ D_0(p)^2&=-s(p)I_{S\otimes F},\\ s(p)&=\sum _j\sin ^2p_j. \end {aligned}\] The square follows from the Clifford anticommutators; the internal factor is the identity. If \(s(p)>0\), the inverse is \(-D_0(p)/s(p)\). If \(s(p)=0\), every sine vanishes and the entire block is zero. A coordinate has only \(p_j=0\) when \(N_j\) is odd, and also \(p_j=\pi \) when it is even. The \(2^e\) choices and complete Fourier decomposition give the asserted dimension. Setting \(q=1\) recovers Proposition [fdip-000T].
For the antiperiodic box, the complete basis from Example [fdip-006J] instead has \(p_j=(2r_j+1)\pi /N_j\). Tensoring with \(S\otimes F\) gives the same matrix symbol and square. In the interval \(0<p_j<2\pi \), the only possible zero is \(p_j=\pi \). The equation \(2r_j+1=N_j\) has one allowed solution exactly when \(N_j\) is odd. Thus there is one zero block if every period is odd and none otherwise. Its dimension is \(q\,2^d\). These scalar seam operators commute in different coordinates; the calculation asserts no such property for arbitrary links.
For two coordinates the explicit comparison is \[\begin {array}{c|ccc} (N_1,N_2)&(4,4)&(4,3)&(3,3)\\\hline \dim \ker D_0&16q&8q&4q\\ \dim \ker D^-&0&0&4q \end {array}\] These are dimensions over \(\mathbb C\) in the chosen reducible module \(S\), with internal multiplicity \(q\). They count exact zero vectors on a finite grid, not physical species or chirality.
Proposition. The corner branches of the centered Dirac symbol [fdip-009R]AGENTDRAFTED
- November 1, 2026
Proposition. The corner branches of the centered Dirac symbol [fdip-009R]AGENTDRAFTED
- November 1, 2026
Extend the free Fourier symbol to the continuous momentum torus \((\mathbb R/2\pi \mathbb Z)^d\): \[\mathcal D(p)=i\sum _j\Gamma _j\sin p_j.\] Its zero matrices occur exactly at the \(2^d\) corners \(p^\epsilon =\pi \epsilon \), with \(\epsilon \in \{0,1\}^d\). Near each corner, \[\begin {aligned} \mathcal D(p^\epsilon +k) &=i\sum _j\widetilde \Gamma _j k_j+O(\|k\|^3),\\ \widetilde \Gamma _j&=(-1)^{\epsilon _j}\Gamma _j, \end {aligned}\] where the remainder is measured in the operator norm on \(S\otimes F\). The matrices \(\widetilde \Gamma _j\) obey the same Clifford anticommutation relations as \(\Gamma _j\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The identity \(\mathcal D(p)^2=-(\sum _j\sin ^2p_j)I\) holds for every real momentum. If \(\mathcal D(p)=0\), its square forces each sine to vanish; conversely those vanishing sines make the matrix zero. Modulo \(2\pi \), each coordinate is \(0\) or \(\pi \). The expansion follows from \(\sin (\pi \epsilon _j+k_j)=(-1)^{\epsilon _j}\sin k_j\) and \(\sin k_j=k_j+O(|k_j|^3)\). The gamma matrices have norm one, and there are finitely many coordinates, so summing the remainders gives the stated operator-norm bound. Finally \[\widetilde \Gamma _i\widetilde \Gamma _j +\widetilde \Gamma _j\widetilde \Gamma _i =2\delta _{ij}I,\] since the two signs cancel when \(i=j\), while the off-diagonal anticommutator was already zero.
Thus the centered symbol has \(2^d\) local first-order branches on the same specified spinor/internal carrier. This is the algebraic doubling mechanism behind the sine propagator and opposite-slope discussion in [wingate2025lattice, Sections 9.1–9.2, Equations (9.6)–(9.7), (9.13)–(9.14), pp. 20–21]. The finite periodic grid samples only \(2^e\) of these corners exactly; an odd period need not sample \(\pi \). Fixed boundary twists alter the allowed momenta, as in Example [fdip-006J], without removing the corners of this symbol.
The chosen \(S\) is reducible, so the number of corners is not a count relative to a minimal physical spinor representation. Nor does the local Taylor expansion construct a quantum continuum limit. The precisely scoped Nielsen–Ninomiya comparison concerns a different theorem: free local translation-invariant Hamiltonians on an infinite odd-dimensional lattice, with isolated relativistic zeros and compatible smooth charge projections. Under its hypotheses the total chiral index vanishes separately for each charge [friedan1982nielsen, Sections 1–2, pp. 481–484; Equations (6), (10)–(11)]. The finite count and the Taylor calculation here do not remove any of those hypotheses or supply that theorem's conclusion.
Remark. Spin-frame compatibility is separate from internal covariance [fdip-009S]AGENTDRAFTED
- November 1, 2026
Remark. Spin-frame compatibility is separate from internal covariance [fdip-009S]AGENTDRAFTED
- November 1, 2026
The internal gauge theorem uses \(I_S\otimes \rho (g(x))\) on field values. It does not cover an arbitrary unitary transformation on \(S\). Already in one coordinate, the chosen gamma matrix is \[X=\begin {pmatrix}0&1\\1&0\end {pmatrix}.\] For \(Z=\operatorname {diag}(1,-1)\), one has \(ZXZ=-X\). With trivial links and fixed lattice directions, \[ZD_0Z=-D_0\ne D_0.\] The inequality holds for every permitted period \(N\ge 3\): the Fourier momentum \(2\pi /N\) has nonzero sine. Thus even a constant unitary change on the spin factor fails the claimed fixed-gamma conjugacy unless the Clifford/frame data are transformed compatibly.
A spin action instead comes with its specified vector action and Clifford compatibility. For a constant orthogonal frame change \(R\), the relevant relation has the form \[\sigma (s)c(v)\sigma (s)^{-1}=c(Rv).\] An action on lattice differences must respect the same change of directions; a varying frame needs additional transport data. No such spin-frame transformation is part of the internal gauge statement above. The compact real Spin cover uses the positive quadratic form, and its action is on the spatial vector carrier. It is not, by its name alone, an action on an arbitrary internal fiber.
In dimension three, the quaternion map \(SU(2)\to SO(3)\) has kernel \(\{1,-1\}\). Its binary finite subgroups supply useful representations, but their roles remain distinct. For example the faithful two-dimensional fiber \(F=\mathbb C^2\) of \(2T\) can be used internally in \(S\otimes F\); then it commutes with the gamma matrices on \(S\). The corresponding three-dimensional rotation representation kills the center and is different data. Neither choice identifies the internal factor with the spatial Clifford module or provides a lattice frame action.
The Wilson term and other doubling remedies [fdip-009T]AGENTDRAFTED
- November 1, 2026
The Wilson term and other doubling remedies [fdip-009T]AGENTDRAFTED
- November 1, 2026
Can the extra zero branches of the centered Dirac operator be lifted without abandoning a local lattice difference? The covariant operator supplies a skew-adjoint first difference. A second difference supplies the Wilson term. For a positive Wilson coefficient and trivial connection, its nonnegative scalar Fourier symbol vanishes only at zero momentum. Adding it to the skew Dirac symbol therefore leaves precisely the constant zero modes.
The factor of lattice spacing and the adjoint convention are part of this statement. Replacing the skew operator by its Hermitian multiple changes the kernel calculation and can create extra zeros. The calculation below uses the already specified reducible Clifford module and internal fiber; it does not identify one surviving momentum block with a minimal physical spinor.
The Wilson term also changes the anticommutation relation with chirality in even dimension. Staggered fields, cochain constructions and the Ginsparg–Wilson relation address different parts of that tradeoff. Their comparison here states the carriers and boundaries of the constructions. The Dirac–Kähler kernels are the comparison in Dirac–Kähler operators.
Definition. The covariant Wilson operator with lattice spacing [fdip-009U]AGENTDRAFTED
- November 1, 2026
Definition. The covariant Wilson operator with lattice spacing [fdip-009U]AGENTDRAFTED
- November 1, 2026
Use the field space and unitary shifts \(\mathcal H=\ell ^2(\Lambda )\otimes S\otimes F\) and \(T_j^U\), with \(\dim _{\mathbb C}S=2^d\) and \(q=\dim _{\mathbb C}F>0\). A lattice spacing \(a>0\) rescales the differences, while \(x\in \Lambda \) remains an integer site label. Define \[\begin {aligned} D_{a,U}&=a^{-1}D_U,\\ L_{a,U}&=a^{-2}\sum _{j=1}^d \bigl (2I-T_j^U-(T_j^U)^{-1}\bigr ). \end {aligned}\] For \(r\in \mathbb R\setminus \{0\}\), the massless Wilson operator in the skew Dirac convention is \[D_{W,a,U}=D_{a,U}+\frac {ra}{2}L_{a,U}.\] The usual positive Wilson coefficient is \(r>0\). For \(a=1\) this is \(D_U+(r/2)L_{1,U}\). The Laplacian is the nearest-neighbor second difference, not the negative square of the centered first difference.
Each \(T_j^U\) is unitary, so \[2I-T_j^U-(T_j^U)^{-1} =(I-T_j^U)^*(I-T_j^U).\] Consequently \(L_{a,U}\) is self-adjoint and nonnegative, whereas \(D_{a,U}\) is skew-adjoint. For the internal gauge transformation \(\mathcal G\) of that proposition, conjugating every shift and its inverse gives \[\begin {aligned} L_{a,U^g}&=\mathcal G L_{a,U}\mathcal G^{-1},\\ D_{W,a,U^g}&=\mathcal G D_{W,a,U}\mathcal G^{-1}. \end {aligned}\] This defines a covariant operator for all the supplied unitary connections. The Fourier kernel theorem below assumes the trivial connection.
For \(r=1\), this is the second-derivative addition in [wingate2025lattice, Section 9.3, Equation (9.15), p. 21]: \(L_a=-\sum _j\nabla _j^+\nabla _j^-\) in the free difference notation. The coefficient \(ra/2\), rather than \(r/2\), is required when \(L_a\) contains \(a^{-2}\). A paired Grassmann quadratic form may use this finite matrix as its kernel, as in Theorem [fdip-008H]. Gauge covariance and the Wilson coefficient alone supply neither a positive probability density nor a fermionic reflection-positive transfer construction.
Theorem. Only the zero-momentum block survives the free Wilson term [fdip-009V]AGENTDRAFTED
- November 1, 2026
Theorem. Only the zero-momentum block survives the free Wilson term [fdip-009V]AGENTDRAFTED
- November 1, 2026
Take the Wilson operator at trivial links, with \(a>0\) and real \(r\ne 0\), on the periodic grid with \(N_j\ge 3\). Its kernel consists exactly of constant fields. In particular, \[\dim _{\mathbb C}\ker D_{W,a,1}=2^d q.\] For the continuous momentum symbol, a corner having \(k\) coordinates equal to \(\pi \) receives scalar Wilson term \(2rk/a\); it is nonzero for \(k\ge 1\).
Proof.
- November 1, 2026
Proof.
- November 1, 2026
The finite Fourier decomposition has momenta \(p_j=2\pi n_j/N_j\), with \(0\le n_j<N_j\). These are dimensionless lattice momenta; their physical representatives are \(p_j/a\). Put \[\begin {aligned} A_a(p)&=\frac {i}{a}\sum _j\Gamma _j\sin p_j,\\ M_a(p)&=\frac {r}{a}\sum _j(1-\cos p_j). \end {aligned}\] The Wilson block is \(A_a(p)+M_a(p)I\). Hermitian gamma matrices and their anticommutation relations give \[\begin {aligned} A_a(p)^*&=-A_a(p),\\ A_a(p)^2&=-a^{-2}\sum _j\sin ^2p_j\,I. \end {aligned}\] Since \(M_a(p)\) is real and scalar, the mixed terms cancel: \[\begin {aligned} &(A_a+M_aI)^*(A_a+M_aI)\\ &\qquad =\left (a^{-2}\sum _j\sin ^2p_j+M_a^2\right )I. \end {aligned}\] Thus a block has a nonzero kernel precisely when both \(\sum _j\sin ^2p_j=0\) and \(M_a(p)=0\). Because \(r\ne 0\) and each \(1-\cos p_j\ge 0\), the latter condition already forces every \(\cos p_j=1\). In the chosen momentum range this means \(p=0\). Conversely the entire block at \(p=0\) is zero. Its dimension is \(\dim (S\otimes F)=2^d q\), and the zero Fourier character is the constant field.
The same formula is defined for every real momentum modulo \(2\pi \). At \(p=\pi \epsilon \), with \(\epsilon \in \{0,1\}^d\), the sine part vanishes and \[M_a(\pi \epsilon )=\frac {2r}{a}\sum _j\epsilon _j.\] This proves the corner claim, whether or not a particular finite grid samples that corner exactly.
For \(q=1\), periods \((4,4)\) and \((4,6)\) both give kernel dimension \(4\); periods \((4,4,4)\) give 8. The same formula applies to odd periods: zero momentum is always present and every other block is invertible.
The scalar addition is the free Wilson denominator mechanism in [wingate2025lattice, Section 9.3, Equations (9.15)–(9.16), p. 21]. For \(r>0\), its value at each nonzero corner grows as \(1/a\). This is an exact free-symbol statement, not a continuum-limit construction or an interacting mass calculation. The cancellation above uses the scalar free block and proves no corresponding kernel formula for a general connection. The surviving block still contains the whole chosen reducible \(S\otimes F\).
Example. The Hermitian convention can retain extra Wilson zeros [fdip-009W]AGENTDRAFTED
- November 1, 2026
Example. The Hermitian convention can retain extra Wilson zeros [fdip-009W]AGENTDRAFTED
- November 1, 2026
Set \(d=1\), \(N=4\), \(a=r=1\), trivial links and \(F=\mathbb C\). The chosen spin space is \(S=\mathbb C^2\), with gamma matrix \[X=\begin {pmatrix}0&1\\1&0\end {pmatrix}.\] The free skew Dirac block is \(D_1(p)=iX\sin p\). Replacing it by the Hermitian operator \(iD_1\) and then adding the same Wilson term gives the block \[H_W(p)=-X\sin p+(1-\cos p)I.\] This is a different operator from Theorem [fdip-009V].
The normalized vectors \((1,1)/\sqrt 2\) and \((1,-1)/\sqrt 2\) are \(X\)-eigenvectors of eigenvalues \(+1\) and \(-1\). Thus the two eigenvalues of \(H_W(p)\) are \(1-\cos p\mp \sin p\). On the 4 allowed momenta: \[\begin {array}{c|cc|c} p&X=+1&X=-1&\dim \ker H_W(p)\\\hline 0&0&0&2\\ \pi /2&0&2&1\\ \pi &2&2&0\\ 3\pi /2&2&0&1 \end {array}\] The total kernel dimension is 4. The skew Wilson operator \(D_1+L_1/2\) instead has kernel dimension two, consisting of constant fields. Tensoring this example with an internal space of dimension \(q\) multiplies both counts by \(q\).
The difference is elementary: a real scalar can cancel a real eigenvalue of the Hermitian first difference. For the skew first difference the squared norm is a sum of nonnegative squares, as in the preceding proof. Adjoint conventions therefore cannot be changed silently in a claim that the Wilson term removes all nonzero-momentum zeros.
Remark. Chirality and the scope of other doubling remedies [fdip-009X]AGENTDRAFTED
- November 1, 2026
Remark. Chirality and the scope of other doubling remedies [fdip-009X]AGENTDRAFTED
- November 1, 2026
In even dimension \(d=2m\), the specified Hermitian gamma matrices define a chirality operator on \(S\otimes F\) by \[C=i^m\Gamma _1\cdots \Gamma _{2m}.\] Write \(P=\Gamma _1\cdots \Gamma _{2m}\). Reversing the order uses \(m(2m-1)\) interchanges, hence \(P^*=(-1)^mP\) and \(P^2=(-1)^mI\). It follows that \(C^*=C\) and \(C^2=I\). Moving one gamma matrix across the other \(2m-1\) factors gives \(C\Gamma _j=-\Gamma _j C\). Since the links act only on \(F\), \(C\) commutes with each shift and with \(L_{a,U}\). Therefore \[\begin {aligned} CD_{a,U}+D_{a,U}C&=0,\\ CD_{W,a,U}+D_{W,a,U}C&=ra\,C L_{a,U}. \end {aligned}\] The second expression is generally nonzero: already at trivial links the nearest-neighbor Laplacian is nonzero on a nonconstant Fourier mode. Thus the Wilson term changes this exact finite anticommutation relation, the algebraic chiral cost discussed in [wingate2025lattice, Section 9.3, p. 21].
Other approaches change different data. The following are source comparisons, not additional equivalence theorems for these finite operators.
- Staggered fields. Spin diagonalization uses a site-dependent product of gamma matrices and then a one-component field with alternating difference signs [wingate2025lattice, Section 9.4, Equations (9.19)–(9.25), pp. 22–23]. The conventional four-dimensional count is 4 tastes relative to minimal four-component Dirac spinors. It is not the number of exact zero modes on a finite grid. In dimension \(4\) the present \(S\) has 16 complex components; no taste identification for that reducible carrier is asserted. On a periodic torus the site-parity transformation also requires compatible even periods or correspondingly changed boundary conditions. No global spin diagonalization on arbitrary odd periods, rooting assertion or continuum equivalence is proved here.
- Dirac–Kähler fields. A geometric route places components on cells of different degrees. Becher and Joos map forms to cochains by integration over cells and use the boundary and coboundary correspondences to write a lattice equation [becher1982dirac, Section 3.1, Equations (3.1)–(3.4), pp. 352–353]. This is taken up in Dirac–Kähler operators. A dimension count does not identify that construction with the present spinor/internal operator, and no such identification or optional cochain construction is made here.
- Ginsparg–Wilson operators. The modified relation \[C\mathcal D+\mathcal D C=a\mathcal D C\mathcal D\] replaces exact anticommutation [wingate2025lattice, Section 9.6, Equation (9.27), p. 24]. If \(\mathcal D\) is invertible, multiplication on both sides by its inverse gives \[C\mathcal D^{-1}+\mathcal D^{-1}C=aC,\] matching the source's contact-term identity (9.28). Neither relation constructs an overlap operator here or follows from the Wilson kernel theorem.
These finite statements do not derive a positive fermion transfer operator or an interacting continuum theory. The reflection-positive transfer construction has its own hypotheses; the choice \(r=1\) does not extend it to a coupled Wilson-fermion action.
Structure [fdip-008R]AGENTDRAFTED
- November 3, 2026
Structure [fdip-008R]AGENTDRAFTED
- November 3, 2026
Can the physics be rebuilt from its observables alone? What replaces calculus when space is discrete?
The chapters below develop these questions. What the structure fixes and what it leaves free records what they fix and what remains an additional input.
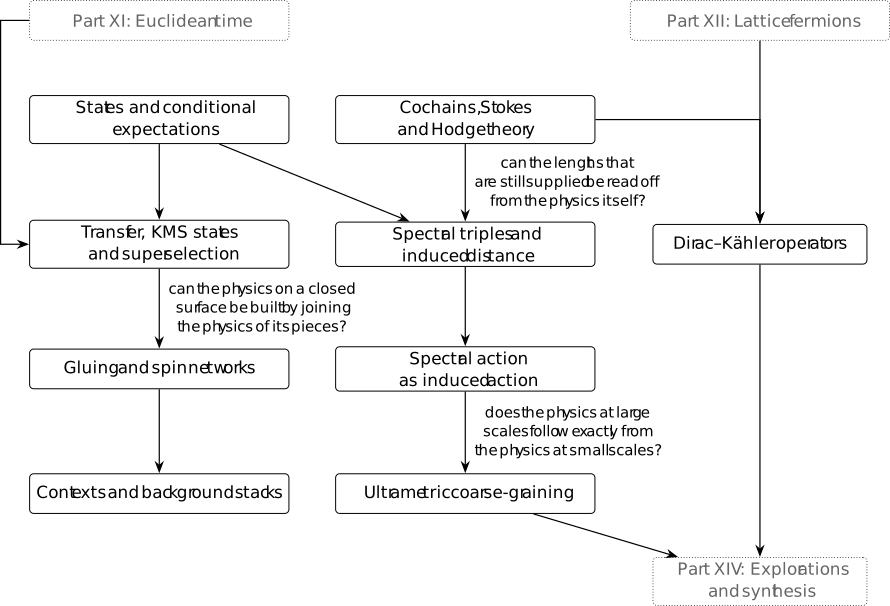
The arrows from Euclidean time enter the transfer chapter; those from lattice fermions enter the Dirac-Kähler chapter. They mark selected intended prerequisites for the chapters below, while the two opening questions motivate the part as a whole. Other suppliers are specified when each construction is developed.
States and conditional expectations [fdip-008S]AGENTDRAFTED
- November 2, 2026
States and conditional expectations [fdip-008S]AGENTDRAFTED
- November 2, 2026
Can the physics be rebuilt from its observables alone? This chapter asks how a state on a finite-dimensional algebra determines a Hilbert space.
The first section builds that space from the Gram form \(\omega (a^*b)\). Its dimension is the rank of the Gram matrix. On a direct sum of matrix algebras that rank is the sum of each block size times the rank of the density, and on functions the space is \(\ell ^2\) of the support. No norm on the algebra is assumed. The following section shows that a Wick conditional expectation sends polynomials to polynomials in the retained variables and that nested retained sets compose. The normalized Grassmann state restricts to the state of the Schur complement.
Theorem. Finite *-algebras, states and GNS [fdip-008T]AGENTDRAFTED
- November 2, 2026
Theorem. Finite *-algebras, states and GNS [fdip-008T]AGENTDRAFTED
- November 2, 2026
A state in the sense of the real and complex algebraic states is a normalized positive functional. That note assumes no norm and no operator representation. On a finite-dimensional *-algebra the functional itself determines both. The squared length of a class is the value of the state on \(\,a^*a\), and the dimension of the resulting space is the rank of one Gram matrix.
Let \(K=\mathbb R\) or \(K=\mathbb C\), and let \(A\) be a finite-dimensional unital associative \(K\)-algebra with an involution of the kind fixed for a real algebraic state or a complex algebraic state. Let \(\omega \) be a real or complex algebraic state on \(A\), according to the scalar field: \(K\)-linear, normalized in the sense of a normalized linear functional, Hermitian positive, and satisfying \(\omega (a^*a)\ge 0\). Define \(\langle x,y\rangle =\omega (x^*y)\). Let \(N\) be the set of \(x\) with \(\langle x,x\rangle =0\). The quotient \(H_\omega =A/N\) carries the descended inner product, the operator \(\pi _\omega (a)\) sends the class of \(b\) to the class of \(ab\), and \(\Omega \) is the class of \(1\).
The form is positive semidefinite and Hermitian, and \(N\) is a left ideal. For the cyclic vector, \[\langle \pi _\omega (a)\Omega ,\pi _\omega (b)\Omega \rangle =\omega (a^*b).\] For any basis the Gram matrix \(G_{ij}=\omega (e_i^*e_j)\) has \(\dim H_\omega =\operatorname {rank} G\). The squared length of the class of \(a\) is \(\omega (a^*a)\).
Let \(A=\bigoplus _i M_{m_i}(K)\), with componentwise product and with conjugate transpose acting on each block. Suppose each \(\rho _i\) has the form \(\rho _i=c_i^*c_i\), and \(\sum _i\mathrm {Tr}(\rho _i)=1\). The functional \(\omega (a)=\sum _i\mathrm {Tr}(\rho _i a_i)\) is a state, and \[\dim H_\omega =\sum _i m_i\operatorname {rank}\rho _i.\] On \(M_2\), the density \(\mathrm {diag}(2/3,1/3)\) has rank \(2\) and gives dimension \(4\). The density \(\mathrm {diag}(1,0)\) has rank \(1\) and gives dimension \(2\).
Let \(X\) be a finite set and let \(A\) be the algebra of functions \(X\to K\), with pointwise product and pointwise conjugation. Let \(w:X\to \mathbb R_{\geq 0}\) satisfy \(\sum _x w(x)=1\), and set \(\omega (f)=\sum _x w(x)f(x)\). Write \(\operatorname {supp} w\) for the labels with \(w(x)>0\). Then \(H_\omega \) is the space of all functions on that support, with the inner product weighted by \(w\). On a finite set that space is \(\ell ^2(\operatorname {supp} w)\).
Equivariant precision and real types records, inside a symmetry sector, a matrix over the reals, the complexes or the quaternions. This section does not prove that those matrices are the blocks of a decomposition of the observable algebra.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The form is linear in the second argument because \(\omega \) is.
It is conjugate-linear in the first because \((\lambda x)^*=\overline \lambda \,x^*\).
It is Hermitian because \(\langle y,x\rangle \) equals \(\omega ((x^*y)^*)\), and Hermitian positivity makes that the conjugate of \(\omega (x^*y)\). The square \(\langle x,x\rangle =\omega (x^*x)\) is nonnegative by the state.
The inequality of Cauchy and Schwarz is \(\lvert \langle x,y\rangle \rvert ^2\le \langle x,x\rangle \langle y,y\rangle \). Over \(\mathbb C\), if \(\langle x,y\rangle \) is not zero, choose a scalar \(u\) of modulus \(1\) with \(u\langle x,y\rangle =\lvert \langle x,y\rangle \rvert \), and replace \(y\) by \(uy\). The new square \(\langle y,y\rangle \) is unchanged, and the new inner product is real and nonnegative. Over \(\mathbb R\) no phase is required. For every real \(t\), \[\langle x+ty,x+ty\rangle =\langle x,x\rangle +2t\langle x,y\rangle +t^2\langle y,y\rangle \ge 0.\] If \(\langle y,y\rangle =0\), the values \(2t\langle x,y\rangle \) cannot stay above \(- \langle x,x\rangle \) for every real \(t\) unless \(\langle x,y\rangle =0\). If \(\langle y,y\rangle >0\), complete the square. The same quadratic is \[\langle y,y\rangle \Bigl (t+\frac {\langle x,y\rangle }{\langle y,y\rangle }\Bigr )^2 +\langle x,x\rangle -\frac {\langle x,y\rangle ^2}{\langle y,y\rangle }.\] The squared term can be made zero, so the remaining term is nonnegative. Thus the inequality holds. Over \(\mathbb C\), putting the unimodular factor back into \(y\) multiplies \(\langle x,y\rangle \) by a scalar of modulus \(1\) and does not change \(\langle y,y\rangle \).
If \(\langle x,x\rangle =0\), the inequality forces \(\langle x,y\rangle =0\) for every \(y\). Conversely the case \(y=x\) shows that the radical is exactly \(N\). It is a subspace. If \(x,y\in N\) and \(\lambda \in K\), then \[\begin {aligned} \langle x+\lambda y,x+\lambda y\rangle ={}&\langle x,x\rangle +\lambda \langle x,y\rangle \\ &+\overline {\lambda }\langle y,x\rangle +\lvert \lambda \rvert ^2\langle y,y\rangle . \end {aligned}\] The two squares vanish because \(x,y\in N\). The two cross terms vanish because an element of \(N\) is orthogonal to every vector. It is a left ideal. For \(b\in A\) and \(x\in N\), \(\langle bx,bx\rangle =\omega (x^*b^*bx)=\langle x,(b^*b)x\rangle =0\).
The form therefore descends to the quotient. If \(x-x'\) and \(y-y'\) lie in \(N\), then \(\langle x,y\rangle -\langle x',y'\rangle =\langle x-x',y\rangle +\langle x',y-y'\rangle \). The first summand vanishes because \(x-x'\) is in the radical. The second is the conjugate of \(\langle y-y',x'\rangle \), which vanishes for the same reason. The descended form is positive definite, and finite dimensionality makes the quotient a Hilbert space with no further completion. Its dimension is \(\dim A-\dim N\).
On a basis \(e_1,\ldots ,e_n\), the matrix \(G_{ij}=\langle e_i,e_j\rangle =\omega (e_i^*e_j)\) is Hermitian. A vector \(v\) represents \(x=\sum _i v_i e_i\). Hermitian symmetry gives \(G_{ji}=\overline {G_{ij}}\). The number \(\langle x,e_j\rangle =\sum _i\overline {v_i}G_{ij}\) vanishes for every \(j\) if and only if \(x\in N\): the forward direction was proved for every vector, and the converse is linearity in the second argument. Conjugating those sums and replacing \(\overline {G_{ij}}\) by \(G_{ji}\) produces \((Gv)_j=0\). Rank-nullity gives \(\operatorname {rank} G=n-\dim N=\dim H_\omega \). The class of \(a\) has squared length \(\omega (a^*a)\). The operator \(\pi _\omega (a)\) is well defined because \(N\) is a left ideal, and \(\langle \pi _\omega (a)\Omega ,\pi _\omega (b)\Omega \rangle =\langle a,b\rangle =\omega (a^*b)\).
On the direct sum, the product and the involution act blockwise, so \(\omega (a^*a)=\sum _i\mathrm {Tr}(\rho _i a_i^*a_i)\). The trace is invariant under a cyclic permutation, and \(\mathrm {Tr}(b^*b)\) is the sum of the squared moduli of the entries of \(b\). Hence \[\mathrm {Tr}(\rho _i a_i^*a_i) =\mathrm {Tr}(c_i a_i^*a_i c_i^*) =\mathrm {Tr}\bigl ((a_i c_i^*)^*(a_i c_i^*)\bigr ),\] which is nonnegative. The functional is therefore positive. It is normalized because \(\omega (1)=\sum _i\mathrm {Tr}(\rho _i)=1\). Each \(\rho _i=c_i^*c_i\) is self-adjoint. The trace of a conjugate transpose is the conjugate of the trace, and \((a_i\rho _i)^*=\rho _i a_i^*\), so \(\mathrm {Tr}(\rho _i a_i^*)=\overline {\mathrm {Tr}(\rho _i a_i)}\). Thus \(\omega \) is Hermitian.
The same identity shows that \(\omega (a^*a)=0\) if and only if \(a_i c_i^*=0\) for every \(i\). Different blocks occupy complementary summands, so \(\dim N=\sum _i\dim \{a_i:a_i c_i^*=0\}\). A matrix vanishes on a subspace precisely when it factors through the quotient by that subspace. The image of \(c_i^*\) has dimension \(\operatorname {rank} c_i^*\). The matrices vanishing on it are determined by their values on a complement, so their space has dimension \(m_i\bigl (m_i-\operatorname {rank} c_i^*\bigr )\). The quotient of that block therefore has dimension \(m_i\operatorname {rank} c_i^*\). Summing over the blocks gives \(\dim H_\omega =\sum _i m_i\operatorname {rank} c_i^*\).
It remains to match that rank with \(\operatorname {rank}\rho _i\). For the standard inner product, \(\|c_i v\|^2=\langle c_i^*c_i v,v\rangle \). If \(c_i^*c_i v=0\), the right-hand side vanishes, so \(c_i v=0\). The converse is immediate, and rank-nullity gives \(\operatorname {rank}\rho _i=\operatorname {rank} c_i\). A minor of a transpose is the transpose of a minor, and the determinant is unchanged by transposition. A minor of a conjugate transpose is the conjugate of a minor of the transpose. The largest size of a nonzero minor is therefore the same for \(c_i\), \(c_i^T\) and \(c_i^*\). Hence \(\operatorname {rank} c_i^*=\operatorname {rank}\rho _i\), and \(\dim H_\omega =\sum _i m_i\operatorname {rank}\rho _i\). On \(M_2\), \(\mathrm {diag}(2/3,1/3)\) is the square of \(\mathrm {diag}(\sqrt {2/3},\sqrt {1/3})\), so its rank is \(2\). \(\mathrm {diag}(1,0)\) is the square of \(\mathrm {diag}(1,0)\), and its only nonzero minor has size \(1\). The formula gives dimensions \(4\) and \(2\).
On functions, the indicator basis is orthogonal for the Gram form. Indeed \(\omega (1_x^*1_y)=\delta _{xy}w(x)\), so the Gram matrix is diagonal with entries \(w(x)\). Its rank is the number of strictly positive weights. A function lies in \(N\) exactly when it vanishes on \(\operatorname {supp} w\), because \(\omega (f^*f)=\sum _x w(x)\lvert f(x)\rvert ^2\). Two functions determine the same class exactly when they agree on that support, and every function on the support arises in this way. The descended inner product is \[\langle f,g\rangle =\sum _{w(x)>0}w(x)\overline {f(x)}\,g(x).\] Every function on a finite set is square-summable, so the space is \(\ell ^2(\operatorname {supp} w)\).
Theorem. Nested conditional expectations compose [fdip-008U]AGENTDRAFTED
- November 2, 2026
Theorem. Nested conditional expectations compose [fdip-008U]AGENTDRAFTED
- November 2, 2026
Let \(A\) be a unital associative algebra and \(\omega \) a linear functional on \(A\). Let \(B\subset A\) be a unital subalgebra. A conditional expectation of \(\omega \) onto \(B\) is a linear map \(E:A\to B\) with \(E(1)=1\), \(E(b_1ab_2)=b_1E(a)b_2\) for \(b_1,b_2\in B\), and \(\omega (E(a))=\omega (a)\). When \(A\) carries the involution of an algebraic state, \(\omega \) is such a state, and \(E(a^*)=E(a)^*\), the same identities give \(\omega (c^*E(a^*a)c)=\omega ((ac)^*(ac))\) for \(c\in B\). No norm on \(A\) enters that identity.
Keep the Wick data of the ring-level moment theorem: \(2\) is a unit, \(Q\) is symmetric and invertible, and \(E_T\) denotes the substitution map of that note onto a retained set \(T\), defined whenever the eliminated block is invertible. For retained sets \(R\subset R'\), write \(U'\) for the complement of \(R'\) and \(V\) for the coordinates in \(R'\) but not in \(R\). Let \(S'\) be the Schur complement of \(Q\) after eliminating \(U'\), and assume that \(Q_{U'U'}\) and the block \((S')_{VV}\) are invertible.
Then \(E_R\) is a conditional expectation of \(\omega _Q\) onto \(A[x_R]\). The two maps compose, \[E_R\circ E_{R'}=E_R.\] On the four-cycle of the moment note, the conditional expectation of the displayed quartic lies in \(\mathbb Q[x_0,x_1]\), and the common value of the two Wick functionals is \(32/75\).
Let \(K\) be an invertible complex matrix, ordered as in the Grassmann Schur formula, with invertible eliminated block \(D\) and Schur complement \(S\). Let \(F\) be a polynomial in the retained paired generators. The normalized state \[\omega _K(F)=\frac {J_n(F e^{-\bar \psi K\psi })}{\det K}\] restricts by \[\omega _K(F)=\omega _S(F).\] Thus the retained state is the normalized Grassmann state of \(S\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The constant \(1\) does not involve the residual indeterminates, and the Wick value of \(1\) is \(1\), so \(E_R(1)=1\). A polynomial \(g\in A[x_R]\) is a coefficient for the residual Wick functional. That functional is linear over \(A[x_R]\), hence \(E_R(gf)=gE_R(f)\). The polynomial ring is commutative, so the two sides of the bimodule identity agree. The moment theorem gives \(\omega _Q(h)=\omega _Q(E_R(h))\) for every polynomial \(h\). Taking \(h=gf\) yields \(\omega _Q(gE_R(f))=\omega _Q(gf)\). The image lies in \(A[x_R]\) by that same theorem.
Apply the moment theorem to the partition \((R',U')\). The residual \(z'=x_{U'}+L'x_{R'}\) is uncorrelated with \(x_{R'}\), and its covariance is \(Q_{U'U'}^{-1}\). The same theorem, applied to the invertible precision \(S'\) and the partition \((R,V)\), produces a residual \(z_V\) in the variables \(x_{R'}\) whose covariance is \((S')_{VV}^{-1}\) and which is uncorrelated with \(x_R\). Second moments of polynomials in \(x_{R'}\) agree under \(\omega _Q\) and under the Wick state of \(S'\), so these two covariances are the moments of \(\omega _Q\). Since \(z_V\) is linear in \(x_{R'}\) and \(z'\) is uncorrelated with \(x_{R'}\), one has \(\omega _Q(z_Vz')=0\).
The moment theorem defines the Schur complement after eliminating \(U'\) by \(S'=Q_{R'R'}-Q_{R'U'}Q_{U'U'}^{-1}Q_{U'R'}\). Its block on \(V\) is therefore \((S')_{VV}=Q_{VV}-Q_{VU'}Q_{U'U'}^{-1}Q_{U'V}\). The same expression is the Schur complement of the invertible block \(Q_{U'U'}\) inside \(Q_{UU}\). That theorem says that, once the eliminated block is invertible, the block matrix is invertible if and only if that Schur complement is. Both are invertible, so \(Q_{UU}\) is invertible, and the one-step map \(E_R\) is defined. Substitute \[x_V=B_Vx_R+z_V\] and then \[x_{U'}=B'x_{R'}+z'.\] The second substitution expands to a retained linear form plus \(B'_Vz_V+z'\). In residual coordinates the change of variables is \[z_U= \begin {pmatrix}I&0\\ B'_V&I\end {pmatrix} \begin {pmatrix}z_V\\ z'\end {pmatrix}.\] The triangular factor has determinant \(1\) and an inverse over \(A\). Both \(z_V\) and \(z'\) are uncorrelated with \(x_R\), so the residual is uncorrelated with \(x_R\). Its retained coefficient is therefore the regression of the moment theorem: the covariance \(C_{RR}\) is invertible, and \(C(x_U,x_R)=BC_{RR}\) determines that coefficient. The one-step residual \(z_U\) is this triangular image.
A pairing in the joint residual that joins \(z_V\) to \(z'\) contributes \(0\). Every surviving pairing is a \(z_V\) pairing times a \(z'\) pairing, so the joint Wick average is the iterated average. The polynomial obtained after the two substitutions is the same polynomial of \(z_U\), and Isserlis' rule depends only on the pairwise covariances of those linear forms. Substitution of \(x_V=B_Vx_R+z_V\) is a ring homomorphism, and the residual Wick functional is linear on coefficients, so the \(z'\) average commutes with that substitution. The average in \(z'\) alone is \(E_{R'}(f)\). Once that polynomial no longer involves \(z'\), the one-step residual average uses only \(z_V\), with covariance \((S')_{VV}^{-1}\). On \(A[x_{R'}]\) that average is \(E_R\). The iterated average is therefore \(E_R(E_{R'}(f))\), and it equals \(E_R(f)\).
For the Grassmann state, the exponential is a sum of even elements. An even element commutes with every homogeneous element, by the Grassmann algebra. The eliminated top word is even, so passing it through the retained polynomial \(F\) contributes no sign. The partial coefficient formula therefore gives \[J_U(F e^{-\bar \psi K\psi }) =\det (D)\,F e^{-\bar \psi _R S\psi _R}.\] Applying \(J_R\) and dividing by \(\det K=\det (D)\det S\) produces \(\omega _S(F)\). The scalar conventions of the empty blocks remain those of the partial formula.
The block factorization used above is the same matrix identity
recorded for the moment theorem. TauCeti's
Matrix.PosDef.gaussianCondCov remains the real
positive-definite covariance, not this tower over a ring. No Mathlib
declaration was found for the Isserlis composition or for the
normalized Grassmann restriction.
No norm-one projection theorem is proved here. Tomiyama's paper of 1957 has not been read. The identities above do not use a norm on the algebra. They also do not identify the Grassmann state with a state on the configuration Clifford algebra.
Transfer, KMS states and superselection [fdip-008V]AGENTDRAFTED
- November 1, 2026
Transfer, KMS states and superselection [fdip-008V]AGENTDRAFTED
- November 1, 2026
How do time evolution and symmetry appear in the language of observables and states? The first section shows that the crossing block of a positive definite precision sets the rank of the linear reflection Gram, and that a finite Gibbs state obeys the conjugation identity. The Gaussian and gauge transfer operators remain the positive operators already constructed for those systems.
The following section asks which observables remain when a symmetry is imposed.
Theorem. The crossing block sets the reflection rank [fdip-008W]AGENTDRAFTED
- November 2, 2026
Theorem. The crossing block sets the reflection rank [fdip-008W]AGENTDRAFTED
- November 2, 2026
Let \(Q\) be a real symmetric positive definite matrix, partitioned into blocks \(Q_{++}\), \(Q_{+-}\), \(Q_{-+}\) and \(Q_{{-}{-}}\), and let \(C=Q^{-1}\). Principal submatrices of a positive definite matrix are positive definite, so \(Q_{++}\) and \(C_{{-}{-}}\) are invertible, and \[\operatorname {rank}C_{+-}=\operatorname {rank}Q_{+-}.\]
On the even torus of the reflection halves, with the spatial factor a point, take the link reflection and the massive scalar law of nearest-neighbor weight \(1\) and mass \(m>0\). The linear reflection Gram matrix, indexed by the positive-half coordinates, has rank \(2\) and is positive semidefinite. The normalized Gaussian transfer operator remains the injective positive contraction of the Hermite diagonalization. The gauge transfer operator remains positive, injective and trace class, as proved for the spatial transfer data.
Let \(H\) be an \(n\times n\) Hermitian matrix and let \(\beta \) be real. The exponential series of a finite matrix converges entrywise. Write \(\rho =e^{-\beta H}/Z\) with \(Z=\operatorname {Tr}(e^{-\beta H})\), and write \(\sigma (A)=e^{-\beta H}Ae^{\beta H}\). The Gibbs state \(\omega (A)=\operatorname {Tr}(\rho A)\) satisfies \[\omega (AB)=\omega (B\sigma (A)).\]
Proof.
- November 2, 2026
Proof.
- November 2, 2026
If \(v\) is a nonzero vector in the first block of coordinates, extend it by zero on the second block. Positive definiteness of \(Q\) gives \(v^TQ_{++}v>0\), so \(Q_{++}\) is positive definite. If \(v\) is a nonzero vector supported on the minus coordinates, extend it by zero on the plus coordinates. Positive definiteness of \(C\) gives \(v^TC_{{-}{-}}v>0\), so \(C_{{-}{-}}\) is positive definite. The off-diagonal block of \(QC=I\) is \[Q_{++}C_{+-}+Q_{+-}C_{{-}{-}}=0.\] Hence \[C_{+-}=-Q_{++}^{-1}Q_{+-}C_{{-}{-}}.\] Left multiplication by the invertible matrix \(Q_{++}^{-1}\) and right multiplication by the invertible matrix \(C_{{-}{-}}\) preserve rank, so the two blocks have the same rank.
For the cycle, the positive half is \(\{1,\ldots ,M\}\) and its image under \(\theta _\ell (t)=1-t\) is the complementary half, with \(M\ge 2\) and length \(2M\). The quadratic form of the massive scalar law has off-diagonal entry \(-1\) on each nearest-neighbor edge and no other off-diagonal entry. The only edges with one end in each half are \(\{0,1\}\) and \(\{M,M+1\}\). Their rows in the positive half are the distinct sites \(1\) and \(M\), and their columns in the negative half are the distinct sites \(0\) and \(M+1\). The crossing block therefore has rank \(2\). The covariance crossing block has the same rank. For real coordinate functions \(x_a\) on the positive half, \(\Theta x_a=x_{\theta (a)}\), so the reflection Gram matrix is that crossing block of \(C\) with columns ordered by \(\theta \). Its rank is \(2\). Every positive-half polynomial lies in the reflection-positive domain of the massive scalar law, so the Gram matrix is positive semidefinite.
Let \(\mu \) bound the absolute values of the entries of \(H\). By induction, the entries of \(H^k\) are at most \(n^{k-1}\mu ^k\). The exponential series is therefore dominated by a scalar exponential and converges entrywise. Since \(H\) commutes with \(-H\), the Cauchy product of the series for \(e^{\beta H}\) and \(e^{-\beta H}\) is the series for \(e^{0}\), which is the identity. The coefficients are real and \(H^*=H\), so \(e^{-\beta H}\) is Hermitian. The same product of series gives \(e^{-\beta H}=e^{-\beta H/2}e^{-\beta H/2}\). For a column \(v\), the squared length \(v^*e^{-\beta H}v\) vanishes only if \(e^{-\beta H/2}v=0\), hence only if \(v=0\). The exponential is positive definite, so its trace \(Z\) is positive. For finite matrices \(\operatorname {Tr}(XY)=\operatorname {Tr}(YX)\). Cycling the first factor gives \[\operatorname {Tr}(e^{-\beta H}Be^{-\beta H}Ae^{\beta H}) =\operatorname {Tr}(Be^{-\beta H}A),\] and cycling \(B\) gives \(\operatorname {Tr}(e^{-\beta H}AB)\). Dividing by \(Z\) is the identity for \(\omega \).
The rank identity uses no reflection. Reflection positivity of the cycle is the massive scalar theorem already cited, and the transfer operators are the two theorems already cited. No infinite volume, no continuum limit, and no claim that the finite Gibbs identity determines a modular operator beyond the displayed conjugation are made here.
Theorem. The fixed-point algebra is the averaged image [fdip-008X]AGENTDRAFTED
- November 2, 2026
Theorem. The fixed-point algebra is the averaged image [fdip-008X]AGENTDRAFTED
- November 2, 2026
Let \(K\) be \(\mathbb R\) or \(\mathbb C\), and let \(A\) be a unital associative \(K\)-algebra. A symmetry of a linear functional \(\omega \) on \(A\) is a unital \(K\)-algebra automorphism \(\alpha \) with \(\omega (\alpha (a))=\omega (a)\) for every \(a\). Let \(G\) be a finite group, and let \(g\mapsto \alpha _g\) be a homomorphism from \(G\) into the unital \(K\)-algebra automorphisms of \(A\), so that \(\alpha _{hg}=\alpha _h\circ \alpha _g\). The order \(|G|\) is invertible in \(K\). Define \[E(a)=\frac 1{|G|}\sum _{g\in G}\alpha _g(a).\] Write \(A^G\) for the fixed-point algebra, the elements fixed by every \(\alpha _g\). Then \(E\) is linear, \(E(1)=1\), the image of \(E\) is \(A^G\), and \(E(b_1ab_2)=b_1E(a)b_2\) whenever \(b_1\) and \(b_2\) are fixed. If every \(\alpha _g\) preserves \(\omega \), then \(\omega (E(a))=\omega (a)\). These are the identities of a conditional expectation of \(\omega \) onto \(A^G\). If every \(\alpha _g\) preserves an involution of \(A\), then \(E(a^*)=E(a)^*\).
When the automorphisms are conjugations \(\alpha _g(R)=\rho (g)R\rho (g)^{-1}\) by a representation \(\rho \) on a finite-dimensional space, the fixed-point algebra is the commutant of \(\rho (G)\). On the half-turn of Proposition [fdip-003T], with \(P=\operatorname {diag}(I_2,-I_2)\) and \(R\) written in those blocks as \(\begin {pmatrix}A&B\\C&D\end {pmatrix}\), the average is the block-diagonal operator \[E(R)=\begin {pmatrix}A&0\\0&D\end {pmatrix}.\] That note identifies this commutant with \(M_2(\mathbb R)\times M_2(\mathbb R)\) and records that the image of the group algebra is the smaller algebra of scalar blocks.
The neutral Gauss constraint for a finite gauge group asks for the link functions fixed by every group element, and its projector is this same average. An invariant functional therefore satisfies \(\omega =\omega \circ E\): its value depends on an observable only through the averaged observable. The charged space remains the intertwiner space of Theorem [fdip-008B]. The multiplicity matrices of a real orthogonal action remain the commutant description of Theorem [fdip-004Z].
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Each \(\alpha _g\) is \(K\)-linear, so \(E\) is linear. A unital automorphism fixes \(1\), and therefore \(E(1)=1\).
For \(h\in G\), \[\alpha _h(E(a)) =\frac 1{|G|}\sum _{g\in G}\alpha _h(\alpha _g(a)) =\frac 1{|G|}\sum _{g\in G}\alpha _{hg}(a).\] As \(g\) runs through \(G\), so does \(hg\). Hence \(\alpha _h(E(a))=E(a)\), and the image of \(E\) lies in \(A^G\).
If \(b\) is fixed by every \(\alpha _g\), every summand equals \(b\), so \(E(b)=b\). Thus \(A^G\) is contained in the image, and \(E\) is the identity on \(A^G\). The two inclusions give \[A^G=\operatorname {im}E.\]
Let \(b_1\) and \(b_2\) be fixed. Multiplicativity gives \(\alpha _g(b_1ab_2)=\alpha _g(b_1)\alpha _g(a)\alpha _g(b_2) =b_1\alpha _g(a)b_2\). Averaging both sides yields \(E(b_1ab_2)=b_1E(a)b_2\).
If every \(\alpha _g\) preserves \(\omega \), then \(\omega (\alpha _g(a))=\omega (a)\). Averaging the scalar values gives \(\omega (E(a))=\omega (a)\). If every automorphism preserves an involution, \(\alpha _g(a^*)=\alpha _g(a)^*\), and the same average gives \(E(a^*)=E(a)^*\).
For a conjugation action, \(\alpha _h(E(R))=E(R)\) is the statement that \(E(R)\) commutes with every \(\rho (h)\). If \(R\) already lies in the commutant, the preceding paragraph gives \(E(R)=R\). Thus the image is exactly the commutant.
In the half-turn coordinates the conjugation by \(P=\operatorname {diag}(I_2,-I_2)\) sends \(\begin {pmatrix}A&B\\C&D\end {pmatrix}\) to \(\begin {pmatrix}A&-B\\-C&D\end {pmatrix}\). The average of the two operators is the displayed block-diagonal matrix. The identification of that commutant, and the comparison with the group-algebra image, are the calculations of Proposition [fdip-003T].
Tomiyama's norm-one projection theorem has not been read, and no norm on \(A\) is used. The argument gives the finite average only. It does not identify the sectors with the centre of the commutant, and it does not replace the charged intertwiner description.
Cochains, Stokes and Hodge theory [fdip-008Y]AGENTDRAFTED
- November 2, 2026
Cochains, Stokes and Hodge theory [fdip-008Y]AGENTDRAFTED
- November 2, 2026
What replaces a derivative when the only space is a grid? The zero-mode count for the centered Dirac operator gives \(\dim _{\mathbb C}\ker D=2^{d+e}\), where \(e\) is the number of even periods among \(N_1,\ldots ,N_d\). For \(d=2\) that dimension is \(2^{2+e}\), so it changes when a side length changes parity.
The square cell complex on the same vertices does not. For every pair of positive integers, the coboundary composed with itself is zero and the real cohomology has dimensions \((1,2,1)\). The following section takes up the adjoint of this coboundary.
Theorem. Square tori have Betti numbers (1, 2, 1) [fdip-008Z]AGENTDRAFTED
- November 2, 2026
Theorem. Square tori have Betti numbers (1, 2, 1) [fdip-008Z]AGENTDRAFTED
- November 2, 2026
Let \(N_1\) and \(N_2\) be positive integers, and set \(V=N_1N_2\). The vertices are the \(V\) pairs \((x,y)\) of integers modulo \(N_1\) and \(N_2\), with addition of coordinates taken modulo those side lengths. For each vertex there is a horizontal edge \(e^h_{x,y}\) from \((x,y)\) to \((x+1,y)\), a vertical edge \(e^v_{x,y}\) from \((x,y)\) to \((x,y+1)\), and a face \(\sigma _{x,y}\). When a side length equals \(1\), each edge in that direction is a loop. The boundary of the face is \[\partial \sigma _{x,y} =e^h_{x,y}+e^v_{x+1,y}-e^h_{x,y+1}-e^v_{x,y}.\]
Real cochains are real functions on these cells. Write \(C^0\), \(C^1\) and \(C^2\) for the functions on vertices, edges and faces, of dimensions \(V\), \(2V\) and \(V\). A chain is a real linear combination of cells of one dimension, and the evaluation pairing \(\langle \beta ,c\rangle \) sums the pointwise products of a cochain with the coefficients of a chain. The coboundary \(d\) is the transpose of the boundary, in the sense that \(\langle d\beta ,c\rangle =\langle \beta ,\partial c\rangle \) whenever the degrees match. On vertex functions this is the incidence map of the ring-valued incidence: \((df)(e)=f(h(e))-f(s(e))\). In coordinates, \[\begin {aligned} (d_0f)^h(x,y)&=f(x+1,y)-f(x,y),\\ (d_0f)^v(x,y)&=f(x,y+1)-f(x,y),\\ (d_1\alpha )(\sigma _{x,y}) &=\alpha ^h(x,y)+\alpha ^v(x+1,y) -\alpha ^h(x,y+1)-\alpha ^v(x,y). \end {aligned}\]
The composite \(d_1\circ d_0\) is zero. Write \(b_0\) for the dimension of \(\ker d_0\), write \(b_1\) for the dimension of the quotient of \(\ker d_1\) by the image of \(d_0\), and write \(b_2\) for the dimension of the quotient of \(C^2\) by the image of \(d_1\). These Betti numbers are \(1\), \(2\) and \(1\).
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Substitute the coordinate formulas. At the face \(\sigma _{x,y}\), \[\begin {aligned} (d_1d_0f)(\sigma _{x,y}) &=\bigl (f(x+1,y)-f(x,y)\bigr )\\ &\quad +\bigl (f(x+1,y+1)-f(x+1,y)\bigr )\\ &\quad -\bigl (f(x+1,y+1)-f(x,y+1)\bigr )\\ &\quad -\bigl (f(x,y+1)-f(x,y)\bigr ). \end {aligned}\] The 8 terms cancel in pairs, so \(d_1d_0f=0\). The pairing separates chains, and therefore the boundary of every face boundary is zero as well.
If \(d_0f=0\), then \(f(x+1,y)=f(x,y)\) and \(f(x,y+1)=f(x,y)\) for every vertex. Following the horizontal steps from \((0,0)\) and then the vertical steps gives \(f(x,y)=f(0,0)\). The kernel consists of the constant functions, so \(\dim \ker d_0=1\) and the rank of \(d_0\) is \(V-1\).
On a single cycle of length \(N\ge 1\), a real function \(g\) on the residues modulo \(N\) is the coboundary of a vertex function if and only if the sum of its values is zero. The forward difference of any vertex function sums to zero. Conversely, if that sum vanishes, set \(f(0)=0\) and let \(f(k)\) be the sum of \(g(0),\ldots ,g(k-1)\) for \(1\le k\le N-1\), with the empty sum equal to zero when \(N=1\). For \(0\le k\le N-2\) the forward difference equals \(g(k)\). The remaining difference is \(f(0)-f(N-1)\). It equals the negative of the sum of \(g(0),\ldots ,g(N-2)\), which the vanishing-sum hypothesis rewrites as \(g(N-1)\). When \(N=1\) both that difference and \(g(0)\) are zero. Thus \(g\) is a coboundary. The functions with vanishing difference are the constants, a one-dimensional space, so the coboundary on the cycle has rank \(N-1\).
Let \(\alpha \) satisfy \(d_1\alpha =0\). Write \(P^h(y)=\sum _x\alpha ^h(x,y)\) and \(P^v(x)=\sum _y\alpha ^v(x,y)\). Sum the face equation over \(x\). The vertical terms cancel because \(x+1\) runs through every residue, and the result is \(P^h(y)=P^h(y+1)\). Sum the face equation over \(y\). The horizontal terms cancel, and the result is \(P^v(x)=P^v(x+1)\). Thus both quantities are constants; call them \(P^h\) and \(P^v\). If \(\alpha =d_0f\), each is a sum of a telescoping difference, so \((P^h,P^v)=(0,0)\).
Conversely, suppose \(d_1\alpha =0\) and \((P^h,P^v)=(0,0)\). For each fixed \(y\), the horizontal row sums to zero, so the cycle criterion supplies a function \(f(\cdot ,y)\) with \(f(0,y)=0\) and horizontal difference \(\alpha ^h\). Define \(\delta (x,y)=\alpha ^v(x,y)-\bigl (f(x,y+1)-f(x,y)\bigr )\). Its horizontal difference is \[\alpha ^v(x+1,y)-\alpha ^v(x,y) -\bigl (\alpha ^h(x,y+1)-\alpha ^h(x,y)\bigr ).\] The face equation rearranges to the vanishing of that expression. Hence \(\delta (x,y)\) depends only on \(y\). The normalization \(f(0,y)=0\) gives the common value \(k(y)=\alpha ^v(0,y)\). The sum of \(k\) is \(P^v=0\), so the cycle criterion supplies \(c\) with \(c(y+1)-c(y)=k(y)\). The function \(f(x,y)+c(y)\) then has horizontal difference \(\alpha ^h\) and vertical difference \(\alpha ^v\). Every cocycle with vanishing periods is therefore a coboundary.
The identity \(d_1d_0=0\) puts the image of \(d_0\) inside \(\ker d_1\). Coboundaries have vanishing periods, and every cocycle with vanishing periods is a coboundary, so that image is exactly the set of cocycles whose periods vanish. The edge field with every horizontal value \(1\) and every vertical value \(0\) has coboundary zero on each face, because the face sees \(+1\) on its lower edge and \(-1\) on its upper edge. Its periods are \((N_1,0)\). The field with the two roles exchanged is likewise a cocycle, with periods \((0,N_2)\). For real \(a\) and \(b\), the combination with horizontal value \(a/N_1\) and vertical value \(b/N_2\) is a cocycle of periods \((a,b)\). The period map on \(\ker d_1\) is therefore a surjective linear map to \(\mathbb R^2\), with kernel equal to the image of \(d_0\). Rank nullity gives \[\dim \ker d_1=(V-1)+2=V+1,\] and the quotient dimension is \[b_1=(V+1)-(V-1)=2.\] The rank of \(d_1\) is \(2V-(V+1)=V-1\).
Summing a coboundary over every face cancels: each horizontal value appears once with each sign as \(y\) runs through a full set of residues, and each vertical value does the same as \(x\) does. The sum of the face values is therefore a linear functional vanishing on the image of \(d_1\). The constant function \(1\) has sum \(V\ne 0\), so the functional is nonzero, its kernel has dimension \(V-1\), and that constant is not a coboundary. The image already has dimension \(V-1\), so the image equals the kernel of the sum. Therefore \(b_2=1\).
The constant vertex functions span the degree-zero cohomology. The two edge fields just named have linearly independent periods, and the degree-one quotient is two-dimensional, so their classes form a basis: one winds around the first coordinate and the other winds around the second. The constant face functions span the degree-two cohomology.
Theorem. Harmonic cochains realize the Betti numbers [fdip-0090]AGENTDRAFTED
- November 2, 2026
Theorem. Harmonic cochains realize the Betti numbers [fdip-0090]AGENTDRAFTED
- November 2, 2026
Let the square torus, its coboundary \(d\), and its evaluation pairing be those of the Betti count. There is no cell below a vertex or above a face, so the coboundary of a face function is zero and there is no adjoint into a vertex from a lower cell. Write \(d^\dagger \) for the adjoint of each coboundary in the evaluation pairing: \(\langle d\gamma ,\beta \rangle =\langle \gamma ,d^\dagger \beta \rangle \). On edge fields this is the counting adjoint. The pairing is symmetric, so \(d\) and \(d^\dagger \) are adjoints of one another, and \(d+d^\dagger \) is self-adjoint. The adjoint of the zero map is zero, and the adjoint reverses composition, so \(d\circ d=0\) gives \(d^\dagger \circ d^\dagger =0\).
On a cochain \(\gamma \) of one degree, define \(\Delta \gamma =d(d^\dagger \gamma )+d^\dagger (d\gamma )\), with either summand omitted when its map has no cells to land on. Call \(\Delta \) the Hodge Laplacian, and call \(\gamma \) harmonic when \(\Delta \gamma =0\). Then \(\Delta =(d+d^\dagger )\circ (d+d^\dagger )\) on each degree. On vertex functions, and with every edge weight equal to \(1\), \(\Delta \) is the unit-weight case of the weighted graph Laplacian. The harmonic cochains in each degree realize the cohomology of that degree, so their dimensions are the Betti numbers \((1,2,1)\). The kernel of \(d+d^\dagger \) therefore has dimension \(4\). A vertex function is the adjoint of an edge field if and only if the sum of its values is zero.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
On a cochain of one degree the two summands of \((d+d^\dagger )\circ (d+d^\dagger )\) are \(d(d^\dagger \gamma )\) and \(d^\dagger (d\gamma )\), because \(d\circ d\) and \(d^\dagger \circ d^\dagger \) vanish. Thus the square is \(\Delta \). Self-adjointness gives \(\langle \Delta \Phi ,\Phi \rangle =\langle (d+d^\dagger )\Phi ,(d+d^\dagger )\Phi \rangle \) for a sum \(\Phi \) of cochains of all three degrees. Expanding the degree-wise formula gives \[\langle \Delta \gamma ,\gamma \rangle =\langle d\gamma ,d\gamma \rangle +\langle d^\dagger \gamma ,d^\dagger \gamma \rangle .\] Both summands are nonnegative, so \(\Delta \gamma =0\) if and only if \(d\gamma =0\) and \(d^\dagger \gamma =0\). The same identity shows that \((d+d^\dagger )\Phi =0\) if and only if every degree of \(\Phi \) is harmonic.
On vertex functions the incoming adjoint is zero, so \(\Delta f=d^\dagger (df)\). The counting adjoint on edge fields is this \(d^\dagger \), and for the constant weight \(1\) the weighted graph Laplacian is \(d_R^\dagger d_R\). The two operators agree.
Fix a degree, and write \(d_-\) for the coboundary into that degree. Its image is contained in the kernel of the outgoing coboundary, because \(d\circ d=0\). The rank of \(d_-^\dagger \) equals the rank of \(d_-\), so the kernel of the adjoint has dimension equal to the dimension of the cochain space minus that rank. Added to the dimension of the image, the total is the whole space. If \(d_-\alpha \) lies in the kernel of \(d_-^\dagger \), then \(\langle d_-\alpha ,d_-\alpha \rangle =\langle \alpha ,d_-^\dagger d_-\alpha \rangle =0\), so \(d_-\alpha =0\). The image therefore meets that kernel only at zero, and the cochain space is their direct sum. A closed cochain splits uniquely as \(d_-\alpha +\rho \) with \(d_-^\dagger \rho =0\). The outgoing coboundary kills \(d_-\alpha \) and kills the sum, so it kills \(\rho \). Thus \(\rho \) is harmonic. The splitting of the closed cochains is direct, and the dimension of the harmonic space is the Betti number of that degree.
On vertices the kernel of \(d\) is the constants. The Betti count gives that kernel dimension \(1\), so the rank of \(d\) is one less than the number of vertices. The image of \(d^\dagger \) from edge fields is orthogonal to that kernel, because \(\langle d^\dagger \alpha ,f\rangle =\langle \alpha ,df\rangle \). The rank of this adjoint equals the rank of \(d\), so the image is the orthogonal complement of the constants. The pairing of a vertex function against the constant \(1\) is the sum of its values, and therefore the complement is the set of vertex functions whose values sum to zero.
The constant vertex functions are harmonic. The two winding edge fields of the Betti count are closed, and each vertex is the head of one edge and the source of one edge in the direction of the winding, with equal values, so the counting-adjoint formula gives zero. The sum of the face values of every coboundary is zero, so the constant face function is orthogonal to every coboundary and its adjoint vanishes. The 4 cochains lie in the three degrees, and the two edge fields are not scalar multiples of one another, so they are linearly independent. The kernel has dimension \(4\), and therefore they form a basis.
Dirac–Kähler operators [fdip-0091]AGENTDRAFTED
- November 2, 2026
Dirac–Kähler operators [fdip-0091]AGENTDRAFTED
- November 2, 2026
The centered Dirac operator on a periodic grid has kernel dimension \(2^{d+e}\), where \(e\) counts the even periods. On a square torus that dimension changes when a side length changes parity. The operator built from the coboundary does not. On every square torus the kernel of \(d+d^\dagger \) has dimension \(4\).
The exterior algebra of a free module carries a multiplication and a contraction for each basis vector. No quadratic form enters those two operations. Their ordered products are every linear endomorphism of the algebra, and the sums of matching pairs obey the Clifford relation of the standard dot product. The following section proves both statements. The section after it takes up the product of cochains.
Theorem. Ordered exterior operators span the endomorphisms [fdip-0092]AGENTDRAFTED
- November 2, 2026
Theorem. Ordered exterior operators span the endomorphisms [fdip-0092]AGENTDRAFTED
- November 2, 2026
On every square torus the kernel of \(d+d^\dagger \) has dimension \(4\), by the Hodge theorem. For periods at least \(3\), the centered Dirac operator has kernel dimension \(2^{2+e}\). That dimension equals \(4\) when both periods are odd, and it is strictly larger when either period is even.
Let \(k\) be a commutative ring and let \(n\) be a positive integer. Write \(\bigwedge \) for the exterior algebra of the free module on basis vectors \(e_1,\ldots ,e_n\), with basis the monomials \(e_I\) indexed by subsets \(I\), written in increasing order, and with \(e_\varnothing =1\). Exterior multiplication and contraction along the basis are the linear operators \[\epsilon _i(e_I)=e_i\wedge e_I,\] \[\iota _i(e_I)=0\] when \(i\notin I\), and, when \(i\) occupies position \(p\) in \(I\), \[\iota _i(e_I)=(-1)^p e_{I\setminus \{i\}}.\] For subsets \(S\) and \(T\), write \(\epsilon _S\) and \(\iota _T\) for the compositions of these operators in increasing index order, the largest index acting first, and write \(M_{S,T}=\epsilon _S\circ \iota _T\). There are \(2^n\) choices for each subset, hence \(4^n\) such operators, and they are a basis of the endomorphism ring of \(\bigwedge \). In particular \(\gamma _i=\epsilon _i+\iota _i\) satisfies \[\gamma _i\gamma _j+\gamma _j\gamma _i=2\delta _{ij}I.\] The configuration Clifford algebra is the square quotient of a supplied quadratic form. The operators here are defined before any such form, and the displayed relation is the square relation of the standard dot product. The note does not claim that the resulting Clifford representation is injective.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The dimension \(4\) is the kernel dimension in the Hodge theorem. The centered count is the cited formula at \(d=2\). It equals \(4\) when \(e=0\). When \(e\ge 1\) the factor \(2^e\) makes it strictly larger. The two statements have the scopes already named.
The monomials are a basis, so operator identities may be checked on \(e_I\). If \(i\in I\), then \(e_i\wedge e_I=0\). If \(i\notin I\) and \(q\) indices of \(I\) are smaller than \(i\), then \(e_i\wedge e_I=(-1)^q e_{I\cup \{i\}}\). Thus \(\epsilon _i^2=0\). For \(i\ne j\) the wedge of the two basis vectors changes sign when their order is exchanged, so \(\epsilon _i\epsilon _j+\epsilon _j\epsilon _i=0\). A monomial contains \(i\) at most once, so \(\iota _i^2=0\).
For the contractions, take \(i\ne j\) and suppose both lie in \(I\), with positions \(p\) and \(r\) and with \(i<j\), so \(p<r\). Removing \(j\) first contributes \((-1)^r\), and \(i\) is still at position \(p\), so the second removal contributes \((-1)^p\). Removing \(i\) first contributes \((-1)^p\), after which \(j\) stands one place earlier, and the second removal contributes \((-1)^{r-1}\). The two signs are opposite, and the remaining monomial is the same. If either index is missing, both double contractions vanish. Hence \(\iota _i\iota _j+\iota _j\iota _i=0\).
Now compare \(\iota _j\epsilon _i\) with \(\epsilon _i\iota _j\). If \(i\ne j\) and \(j\notin I\), the contraction of the input is zero. Exterior multiplication either vanishes or produces a monomial that still omits \(j\), so the later contraction vanishes as well. If \(j\in I\) and \(i\in I\), exterior multiplication of the input vanishes, and the contraction still leaves \(i\) in place, so the later exterior multiplication vanishes. The remaining pattern is \(j\in I\) and \(i\notin I\). Let \(p\) be the position of \(j\) and let \(q\) be the number of indices of \(I\) smaller than \(i\). Removing \(j\) contributes \((-1)^p\). If \(i<j\), wedging \(e_i\) back contributes the same sign \((-1)^q\) that \(e_i\wedge e_I\) carries, while the later removal of \(j\) from \(I\cup \{i\}\) contributes \((-1)^{p+1}\), because \(i\) stands before \(j\). If \(i>j\), wedging \(e_i\) after the removal contributes \((-1)^{q-1}\), because \(j\) was one of the indices counted by \(q\), while the removal of \(j\) from \(I\cup \{i\}\) still contributes \((-1)^p\). In both subcases the two compositions land on the same monomial with opposite signs. If \(i=j\) and \(i\notin I\), the contraction of the input vanishes and \(\iota _i\epsilon _i\) returns \(e_I\), and the product of the two signs \((-1)^q\) is \(1\). If \(i\in I\), exterior multiplication of the input vanishes and \(\epsilon _i\iota _i\) returns \(e_I\), and the product of the two signs \((-1)^p\) is \(1\). Therefore \(\epsilon _i\iota _j+\iota _j\epsilon _i=\delta _{ij}I\).
The square of \(\gamma _i\) is \(\epsilon _i\iota _i+\iota _i\epsilon _i=I\). For \(i\ne j\) each of the 4 pairs in the expansion of \(\gamma _i\gamma _j+\gamma _j\gamma _i\) anticommutes, so the sum is zero. This is the displayed Clifford relation.
The monomials are a free basis, so the endomorphism ring is free on the operators that send one monomial to one monomial and kill the rest. Order the pairs of subsets so that the cardinality of \(T\) increases, and index both the operators \(M_{S,T}\) and these monomial matrix units by that order. The coefficient of \(e_S\) in \(M_{S',T'}e_T\) can be nonzero only when \(T'\subseteq T\). A column with a strictly larger second set therefore does not meet this row. When the cardinalities are equal, necessarily \(T'=T\). The contraction \(\iota _T\) removes every factor of \(e_T\). Each removal meets a present factor, so the image of the contraction is \((\pm 1)\,1\). The following exterior product inserts the factors in \(S'\), each into a monomial that does not yet contain it, and the image is \((\pm 1)\,e_{S'}\). The coefficient of \(e_S\) is therefore zero unless \(S'=S\), in which case it is \(\pm 1\). Within one cardinality the block is diagonal. A strictly smaller \(T'\) meets the row in an earlier column. The matrix is consequently lower triangular, with units \(\pm 1\) on the diagonal. Given a target endomorphism, its coefficients against the \(M_{S,T}\) are the unique solution of that system: start from the empty second set, invert the diagonal unit, and at each later row use the coefficients already found. The operators are therefore a basis.
For a single basis vector the 4 operators are the identity, exterior multiplication, contraction, and their composite. On a space of dimension \(2\) any 4 independent endomorphisms are a basis, and the triangular count supplies the independence.
Theorem. The cup product obeys graded Leibniz [fdip-0093]AGENTDRAFTED
- November 2, 2026
Theorem. The cup product obeys graded Leibniz [fdip-0093]AGENTDRAFTED
- November 2, 2026
Let the vertices of a finite simplicial complex be ordered, and let a cochain take values in a commutative ring. On an increasing simplex the cup product of a cochain \(\alpha \) of degree \(k\) and a cochain \(\beta \) of degree \(l\) reads the front face of dimension \(k\) and the back face of dimension \(l\): \[(\alpha \cup \beta )(v_0,\ldots ,v_{k+l}) =\alpha (v_0,\ldots ,v_k)\,\beta (v_k,\ldots ,v_{k+l}).\] The coboundary is the alternating sum of the faces with one vertex removed. Then \[d(\alpha \cup \beta )=(d\alpha )\cup \beta +(-1)^k\alpha \cup (d\beta ).\] The same formula does not make the product graded-commutative on cochains.
Let \(G\) be a group and let the transport of a path be the one in the plaquette convention: the first edge stands on the right, and a reversed edge contributes the inverse. On the rectangle with \(M\) squares horizontally and \(N\) squares vertically, label the square whose lower-left corner is \((i,j)\) by \(p_{i,j}\). Let \(\gamma _{i,j}\) run from the lower-left corner of the rectangle along the bottom to column \(i\) and then up to row \(j\). The boundary holonomy, traversed counterclockwise from that corner, equals \[\prod _{i=0}^{M-1}\prod _{j=N-1}^{0} U_{\gamma _{i,j}}^{-1}U_{p_{i,j}}U_{\gamma _{i,j}},\] with the left column on the left of the product and, inside a column, the top square on the left.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Evaluate both sides of the Leibniz identity on an ordered simplex of dimension \(k+l+1\), with vertices \(v_0\) through \(v_{k+l+1}\). The coboundary of the product is the alternating sum of the products on the faces. On the face that omits \(v_i\) with \(i\le k\), the front face of dimension \(k\) is \((v_0,\ldots ,\widehat {v_i},\ldots ,v_{k+1})\) and the back begins at \(v_{k+1}\). Those are the terms \(i\le k\) of \((d\alpha )\cup \beta \). On the face that omits \(v_i\) with \(i\ge k+1\), write \(j=i-k\). The front is \((v_0,\ldots ,v_k)\) and the back omits the vertex of index \(j\) in \((v_k,\ldots ,v_{k+l+1})\). The sign \((-1)^{k+j}\) is the sign in \((-1)^k\alpha \cup (d\beta )\). The two sums therefore share every face except the face \(i=k+1\) of \((d\alpha )\cup \beta \) and the face \(j=0\) of \((-1)^k\alpha \cup (d\beta )\). Those two faces are the same product \(\alpha (v_0,\ldots ,v_k)\beta (v_{k+1},\ldots ,v_{k+l+1})\), with signs \((-1)^{k+1}\) and \((-1)^k\), which add to zero.
On the simplex \((0,1,2)\), let \(\alpha \) and \(\beta \) be \(1\)-cochains with \(\alpha (0,1)=1\), \(\alpha (1,2)=0\), \(\beta (0,1)=0\) and \(\beta (1,2)=1\). Then \((\alpha \cup \beta )(0,1,2)=1\) and \((\beta \cup \alpha )(0,1,2)=0\). The two products differ as cochains. This note does not prove that their difference becomes a coboundary after both factors are closed.
Write \(U_{p}\) for the plaquette holonomy. For the square with lower-left corner \((i,j)\), if \(b\) is its bottom edge, \(r\) its right edge, \(t\) its top edge and \(s\) its left edge, each oriented rightward or upward, then \(U_p=s^{-1}t^{-1}rb\). The displayed product is proved by adding columns from the left. A single column has bottom edge \(b_0\), right edges \(r_0,\ldots ,r_{N-1}\) from bottom to top, top edge \(t\), and left edges \(s_0,\ldots ,s_{N-1}\). Its boundary transport is \(s_0^{-1}\cdots s_{N-1}^{-1}t^{-1}r_{N-1}\cdots r_0b_0\). The path \(\gamma _{0,j}\) is the left side up to height \(j\), with transport \(\sigma _j=s_{j-1}\cdots s_0\) and \(\sigma _0=1\). One square is already the boundary word. For several squares the conjugate by \(\sigma _j^{-1}\) is \(\sigma _j^{-1}s_j^{-1}t_j^{-1}r_jb_j\sigma _j\). In the product from the top of the column down to the bottom, the junction of the square at height \(j\) with the square below it is \(\sigma _j\sigma _{j-1}^{-1}s_{j-1}^{-1}=1\), because \(\sigma _j=s_{j-1}\sigma _{j-1}\), and \(b_jt_{j-1}^{-1}=1\), because the bottom of the upper square is the top of the square below it. The right edges remain in order from the top down, and the surviving left edge is the full inverse \(s_0^{-1}\cdots s_{N-1}^{-1}\). The product is the boundary word.
Suppose the identity holds for the rectangle with \(M-1\) columns, and attach one column on the right. The conjugating paths of the columns already present do not use the new column, so the inductive product is the old boundary transport times the new column product, the new factor standing on the right. Let \(\beta \) be the transport along the old bottom, \(S\) the transport up the shared vertical side, \(T\) the reversed old top and \(L\) the reversed left side. The old boundary transport is \(LTS\beta \). The new boundary inserts the new bottom edge \(b_0\) after \(\beta \), replaces the shared side by the new right side \(R\), and inserts the inverse of the new top edge \(t\) before \(T\). Its transport is \(LTt^{-1}Rb_0\beta \). Each new path is the old bottom followed by the upward path of the previous paragraph, so each new conjugate is \(\beta ^{-1}\) times the corresponding column factor times \(\beta \). Between successive squares \(\beta \) meets \(\beta ^{-1}\), and the product of those conjugates is \(\beta ^{-1}S^{-1}t^{-1}Rb_0\beta \). Here \(S\) is the upward transport of the shared side, lowest edge on the right, so \(\beta ^{-1}S^{-1}\) is the inverse of the path along the old bottom and then up that side. Multiplying on the left by \(LTS\beta \) cancels \(\beta \) against \(\beta ^{-1}\) and \(S\) against \(S^{-1}\), and leaves the new boundary transport. Finiteness of the group is not used.
Spectral triples and induced distance [fdip-0094]AGENTDRAFTED
- November 2, 2026
Spectral triples and induced distance [fdip-0094]AGENTDRAFTED
- November 2, 2026
Can a distance on a finite set be read from an operator, rather than from edge weights supplied with the complex?
On three points the commutator of a real symmetric matrix with a function determines the distance by a closed formula. On the path of 4 vertices that distance is \(2\), while the graph distance is \(3\). The following section proves both evaluations. The section after it takes up operators that see the edges.
Theorem. Finite spectral triples and the Connes distance [fdip-0095]AGENTDRAFTED
- November 2, 2026
Theorem. Finite spectral triples and the Connes distance [fdip-0095]AGENTDRAFTED
- November 2, 2026
The naive lattice Dirac operator does not reproduce lattice spacing.
[bimonte1994lattice, equation (45)] computes the distances along one axis. For one, two, three and 4 steps they are \(2a\), \(2\sqrt {2}\,a\), \(4a\) and \(2\sqrt {6}\,a\). Those are not the multiples \(a\), \(2a\), \(3a\) and \(4a\).
A Wilson term multiplies every one of those distances by \((1+r^{2})^{-1/2}\).
[bimonte1994lattice, the paragraph containing (47)] records that rescaling.
Let \(D\) be a real symmetric \(3\times 3\) matrix, and let a real function on its three indices act by the diagonal matrix \(f\). The distance from index \(1\) to index \(2\) is the supremum of \(|f_2-f_1|\) over all \(f\) with \(|[D,f]|\le 1\). Write \(D_{ij}\) for the entries of \(D\) and \[\Delta =D_{12}^{2}D_{13}^{2}+D_{12}^{2}D_{23}^{2}+D_{13}^{2}D_{23}^{2}.\] If \(\Delta >0\), the distance is \[\sqrt {\frac {D_{13}^{2}+D_{23}^{2}}{\Delta }}.\] If \(D_{13}=D_{23}=0\) and \(D_{12}\ne 0\), the distance is \(1/|D_{12}|\). In every remaining case there is no finite upper bound. The distances among the other pairs are the same statements with the indices cycled.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The commutator has entries \([D,f]_{ij}=D_{ij}(f_j-f_i)\). Adding a constant to \(f\) does not change it, so set \(f_1=0\), \(f_2=x\) and \(f_3=y\). The entries above the diagonal are \(a=D_{12}x\), \(b=D_{13}y\) and \(c=D_{23}(y-x)\). Let \(\omega =(-c,b,-a)\) and let \(\sigma ^{2}=a^{2}+b^{2}+c^{2}\). Write \(M\) for the matrix of \([D,f]\). It is skew-symmetric, so its square is the negative of \(M^{\mathrm T}M\). Expanding that product gives \(M^{\mathrm T}M=\sigma ^{2}I-\omega \omega ^{\mathrm T}\). Thus \(M^{\mathrm T}M\) fixes the line through \(\omega \) by \(0\) and acts as \(\sigma ^{2}\) on the orthogonal plane. The operator norm of \([D,f]\) is therefore \(\sigma \). The constraint \(\sigma \le 1\) reads \[(D_{12}^{2}+D_{23}^{2})x^{2}-2D_{23}^{2}xy+(D_{13}^{2}+D_{23}^{2})y^{2}\le 1.\]
Write \(A=D_{13}^{2}+D_{23}^{2}\). If \(A>0\), the left side is a quadratic polynomial in \(y\) opening upwards. The discriminant of this polynomial set equal to \(1\) is \(4A-4\Delta x^{2}\). A real \(y\) exists exactly when this discriminant is nonnegative. If \(\Delta >0\), that condition is \(x^{2}\le A/\Delta \), so the largest value of \(|x|\) is the displayed square root. If \(\Delta =0\), the discriminant is positive for every \(x\), and there is no finite upper bound.
If \(A=0\), then \(D_{13}=D_{23}=0\) and the constraint reduces to \(D_{12}^{2}x^{2}\le 1\). A nonzero \(D_{12}\) gives the reciprocal bound. If \(D_{12}\) vanishes as well, every \(x\) is allowed. Since \(A=0\) forces \(\Delta =0\), this case and the case \(A>0\) with \(\Delta =0\) cover every vanishing \(\Delta \).
On the path with vertices \(0,1,2,3\) and the adjacency matrix as \(D\), the same commutator norm gives distance \(2\) from \(0\) to \(3\). The graph distance along the three edges is \(3\). Let \(a=f_1-f_0\), \(b=f_2-f_1\) and \(c=f_3-f_2\), so \(f_3-f_0=a+b+c\). The commutator is zero except for these three adjacent pairs. Replacing each difference by its absolute value does not change the operator norm: the signs are absorbed by changing the signs of the last three basis vectors. Thus it is enough to take \(a,b,c\ge 0\).
Suppose \(a+b+c>2\). If \(a\ge 2\), the first basis vector is sent to a vector of length \(a\), so the norm exceeds \(1\). If \(a<2\), then \(b+c>2-a\). The vector \((0,1,0,-1)\) has length \(\sqrt {2}\) and is sent to \((a,0,-(b+c),0)\), whose square length is \(a^{2}+(b+c)^{2}\). That square exceeds \(a^{2}+(2-a)^{2}=2(a-1)^{2}+2\ge 2\), so the operator norm exceeds \(1\). Therefore every admissible triple has \(a+b+c\le 2\).
The values \(a=c=1\) and \(b=0\) give \(f=(0,1,1,2)\). The commutator is the orthogonal sum of two copies of the block with entries \(0,1,-1,0\), and each block has norm \(1\). The difference of the endpoint values is \(2\), so the distance is exactly \(2\).
[iochum1999distances, Theorem 9] proves a complementary fact for a general real symmetric matrix on 4 indices: the distance is a root of a polynomial of degree at most \(12\), and that polynomial is generically not solvable by radicals. The path above is one matrix for which the distance can still be read off directly. This note does not reproduce the degree count.
Theorem. The edge-source triple and inner fluctuations [fdip-0096]AGENTDRAFTED
- November 3, 2026
Theorem. The edge-source triple and inner fluctuations [fdip-0096]AGENTDRAFTED
- November 3, 2026
Let \(G\) be a finite oriented graph, with vertex set \(V\) and edge set \(E\). Write \(s(e)\) and \(h(e)\) for the source and head of an edge. No edge is a loop. Let the real Hilbert space have the counting inner product and the orthonormal basis indexed by \(V\) and by \(E\). Define \[(d_E\xi )(e)=\xi (h(e))-\xi (s(e)).\] Let \(D\) be the self-adjoint operator whose vertex-to-edge block is \(d_E\) and whose edge-to-vertex block is the adjoint \(d_E^{\dagger }\). A real function \(f\) on \(V\) acts by multiplication by \(f(v)\) on vertex \(v\) and by multiplication by \(f(s(e))\) on edge \(e\).
The operator norm of the commutator is read from the jumps on the edges that enter each vertex. For every vertex \(v\), \[\bigl |[D,f]\bigr | =\max _v\Bigl (\sum _{h(e)=v}\bigl (f(h(e))-f(s(e))\bigr )^{2}\Bigr )^{1/2}.\] If every vertex has at most one incoming edge, this norm is the maximum of \(|f(h(e))-f(s(e))|\) over the edges. On each connected component of the underlying undirected graph, the supremum \[\sup \bigl \{|f(j)-f(i)|:\bigl |[D,f]\bigr |\le 1\bigr \}\] equals the least number of edges joining the two vertices. Between distinct components that supremum is infinite. A directed cycle has one incoming edge at each vertex, so opposite vertices of a directed \(6\)-cycle are at distance \(3\).
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Write \(\delta _e=f(h(e))-f(s(e))\). The edge component of \([D,f]\) applied to \((\xi ,\psi )\) is \(\delta _e\xi (h(e))\), and the vertex component is the negative adjoint of that edge map applied to \(\psi \). The operator norm is therefore the norm of the edge map \(C\xi (e)=\delta _e\xi (h(e))\). Its square length is \[\|C\xi \|^{2}=\sum _v\xi (v)^{2}\sum _{h(e)=v}\delta _e^{2}.\] The vertex basis is orthonormal, so the second sum is the eigenvalue at \(v\). The largest square root is the displayed maximum.
If each vertex has at most one incoming edge, the inner sum is a single square, and the norm is the largest absolute jump. The constraint then says that \(|f(h)-f(s)|\le 1\) on every edge. The graph-distance function from \(i\) changes by at most \(1\) along an edge, so it is allowed, and its value at \(j\) is the graph distance. Any allowed function changes by at most \(1\) along each edge, so it cannot exceed that distance. If no path joins \(i\) to \(j\), adding a constant on the component of \(j\) does not change the commutator, and the difference is unbounded.
The same norm is stricter where a vertex has two incoming edges. On the grid whose coordinates each run through \(0,1,2\), orient each edge in the positive direction of one axis. The distance from \((0,0)\) to \((1,1)\) is \(1+1/\sqrt {2}\). The Euclidean distance is \(\sqrt {2}\) and the graph distance is \(2\), and the commutator distance lies strictly between them.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Write \(x=f(1,0)-f(0,0)\), \(y=f(0,1)-f(0,0)\), \(p=f(1,1)-f(1,0)\) and \(q=f(1,1)-f(0,1)\). The vertex \((1,0)\) has only the incoming edge from \((0,0)\), and \((0,1)\) has only the incoming edge from \((0,0)\), so an allowed function satisfies \(x^{2}\le 1\) and \(y^{2}\le 1\). The vertex \((1,1)\) has those two incoming edges, so \(p^{2}+q^{2}\le 1\). The difference \(\delta =f(1,1)-f(0,0)\) equals both \(x+p\) and \(y+q\). Thus \((\delta -x)^{2}+(\delta -y)^{2}\le 1\) for some \(x,y\) in the interval from \(-1\) to \(1\). If \(\delta >1+1/\sqrt {2}\), then both \(\delta -x\) and \(\delta -y\) exceed \(1/\sqrt {2}\), and the sum of squares exceeds \(1\). Hence \(\delta \le 1+1/\sqrt {2}\).
The bound is attained by \(f(0,0)=0\), \(f(1,0)=f(0,1)=f(2,0)=1\), \(f(0,2)=1\), and the value \(1+1/\sqrt {2}\) at the other 4 vertices. The incoming square sums are \(1\) at \((1,0)\), \((0,1)\) and \((1,1)\), they are \(1/2\) at \((2,1)\) and \((1,2)\), and they vanish elsewhere. The norm is \(1\), and the difference of the endpoint values is \(1+1/\sqrt {2}\). It is larger than \(\sqrt {2}\) because \(1>1/\sqrt {2}\), and it is smaller than \(2\) because \(1/\sqrt {2}<1\).
Inner fluctuations fill the head slots of \(D\). For real functions \(a\) and \(b\), the edge component of \(a[D,b]\) applied to a vertex vector \(\xi \) is \[e\mapsto a(s(e))\bigl (b(h(e))-b(s(e))\bigr )\xi (h(e)).\] Suppose that at most one edge runs from any vertex to any other, and that the opposite orientation is absent. For an edge \(e\) from \(s\) to \(h\) and a real scalar \(c\), let \(a\) equal \(c\) at \(s\) and equal \(0\) elsewhere, and let \(b\) equal \(1\) at \(h\) and equal \(0\) elsewhere. The sum \(S=a[D,b]+b[D,a]\) is self-adjoint. Its edge component is \(c\,\xi (h)\) on \(e\) and zero on every other edge. Summing one such operator for each edge gives every real assignment \((c_e)\). Adding that sum to \(D\) replaces the edge formula by \[U_e\xi (h(e))-\xi (s(e)),\qquad U_e=1+c_e.\]
Proof.
- November 3, 2026
Proof.
- November 3, 2026
The displayed edge formula for \(a[D,b]\) is the commutator calculation already used for the norm: the terms in which \(b\) is read at the source cancel, and multiplication by \(a\) is evaluated at the source. With the two functions just chosen, \(a(s(e'))(b(h(e'))-b(s(e')))\) equals \(c\) on the edge from \(s\) to \(h\) and equals \(0\) on every other edge. The swapped product \(b(s(e'))(a(h(e'))-a(s(e')))\) is nonzero only on an edge from \(h\) to \(s\). No such edge is present.
It remains to check that \(b[D,a]\) is the adjoint of \(a[D,b]\). The edge block of \(a[D,b]\) multiplies the value at \(h\) by \(c\) and places it on \(e\). Its adjoint therefore multiplies the value on \(e\) by \(c\) and places it at \(h\). The vertex component of a commutator \(p[D,q]\), evaluated at a vertex \(v\), is \[-p(v)\sum _{h(e')=v}\bigl (q(h(e'))-q(s(e'))\bigr )\psi (e').\] For \(p=b\) and \(q=a\), the only vertex where \(b\) is nonzero is \(h\). The only incoming edge there whose source carries a nonzero value of \(a\) is \(e\), and on that edge \(a(h)-a(s)=-c\). The leading minus sign turns that term into \(c\,\psi (e)\) at \(h\), and the component is \(0\) at every other vertex. The two blocks agree. For the other pair, the vertex component of \(a[D,b]\) is supported at \(s\), and no edge entering \(s\) starts at \(h\), so that component is \(0\). The edge component of \(b[D,a]\) is \(0\) because the reverse edge is absent. Hence \(S\) is self-adjoint and its edge coefficient on \(e\) is \(c\).
The coefficients \(U_e\) constructed above are real. When \(U_e\ne 0\), \[U_e\xi (h(e))-\xi (s(e)) =U_e\bigl (\xi (h(e))-U_e^{-1}\xi (s(e))\bigr ).\] The second factor is the covariant difference of the scalar connection \(U_e^{-1}\). The two edge maps have the same kernel. This construction does not produce a matrix representation of a nonabelian group.
If every \(U_e\) equals \(\pm 1\), multiplication by \(U_e\) is an orthogonal map \(W\) of the edges, and \(W^{-1}=W\). Let \(d_1\) be the covariant difference and set \(d_2=Wd_1\). Then \(d_2^{\dagger }=d_1^{\dagger }W\). Conjugating the off-diagonal operator of \(d_2\) by the orthogonal map that is the identity on vertices and \(W\) on edges replaces the edge block \(d_2\) by \(Wd_2=d_1\) and replaces \(d_2^{\dagger }\) by \(d_1^{\dagger }\). The two self-adjoint operators are orthogonally equivalent.
Spectral action as induced action [fdip-0097]AGENTDRAFTED
- November 3, 2026
Spectral action as induced action [fdip-0097]AGENTDRAFTED
- November 3, 2026
Can a gauge weight be read from the spectrum of an operator that the graph already determines, rather than supplied as a face term?
On a triangle-free graph, the gauge-dependent part of the fourth power of the massless covariant Laplacian is 8 times a sum over 4-cycles. The following section proves that identity and says when those cycles are the plaquettes of a square torus. A comparison with the logarithm of the massive precision, and with a continuum limit cited in that section, remains speculative.
Theorem. Four-cycles determine the fourth-power trace [fdip-00A7]AGENTDRAFTED
- November 3, 2026
Theorem. Four-cycles determine the fourth-power trace [fdip-00A7]AGENTDRAFTED
- November 3, 2026
Let \(G\) be a finite undirected simple graph, with no loops and no multiple edges, and assume \(G\) is triangle-free. Let each undirected edge \(e\) receive one orientation, from a source \(s(e)\) to a head \(h(e)\), and a transport \(U_e\in U(1)\). The reverse orientation carries \(U_e^{-1}\). For unit weights and vanishing mass, the connection background supplies the covariant Laplacian \(L_U\) on complex functions of the vertices. Its matrix in the standard basis is \[L_{h(e),s(e)}=-U_e,\qquad L_{s(e),h(e)}=-U_e^{-1},\qquad L_{vv}=\deg (v),\] and every other entry is zero. The same formula with every transport equal to \(1\) is written \(L_1\). Both operators are Hermitian, so the two traces below are real.
Write \(A\) for the off-diagonal part, so \(L_U=D-A\) with \(D\) the diagonal matrix of degrees. Thus \(A_{h(e),s(e)}=U_e\). For a 4-cycle \(c\), choose either orientation and let \(e^{i\varphi _c}\) be the product of the 4 transports along it. The opposite orientation gives the complex conjugate, so \(\cos \varphi _c\) does not depend on the choice.
The gauge-dependent part of the fourth-power trace is 8 times the sum of \(\cos \varphi _c-1\) over the undirected 4-cycles of \(G\), each taken once: \[\operatorname {Tr}L_U^4-\operatorname {Tr}L_1^4 =8\sum _c(\cos \varphi _c-1).\]
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Expand the trace as a sum over quadruples of vertices. A factor \(L_{xy}\) is a diagonal degree when \(x=y\), and an off-diagonal transport when the two indices are the ends of an edge. The degree matrix does not depend on the connection. It is enough to show that every summand with fewer than 4 off-diagonal factors takes the same value at \(U\) and at the trivial connection, and then to evaluate the four-transport walks.
One off-diagonal factor cannot occur. The other three factors are diagonal, so they force all 4 vertices to agree, and \(A\) has zero diagonal. Three off-diagonal factors leave one stationary vertex and three steps. Those three steps would be a closed walk of length 3. No such walk exists: a simple graph has no loop that could close in one step, two vertices determine only one edge and an odd number of crossings of that edge ends at the other vertex, and three vertices of a closed walk would form a triangle. Thus every contribution with one or three off-diagonal factors vanishes for every connection.
Two off-diagonal factors are transports across one edge and back across the same edge. The other two factors are diagonal, so each equates its two indices. Rotating the 4 positions, the two moving steps are either consecutive or separated by a stay. In the consecutive case the walk leaves a vertex and returns on the next step. In the separated case it makes the same return after the stay. Either way the two steps are inverses, and a simple graph has only one edge between those vertices. The product of a transport with its inverse is \(1\), for every value in \(U(1)\). These summands therefore agree with the trivial connection.
The remaining sum is \(\operatorname {Tr}A_U^4-\operatorname {Tr}A_1^4\). Each of the 4 minus signs in \(L=D-A\) contributes a factor \(-1\), and 4 of them multiply to \(1\), so this is also the difference of the four-transport parts of \(\operatorname {Tr}L^4\). A summand is the product of the entries of \(A\) around a closed walk of length 4. If that walk is not a simple cycle, then it visits at most three vertices. The edges it actually uses form a connected subgraph of a triangle-free simple graph on those vertices, hence a tree. On a tree every closed walk has transport product \(1\): the first time the walk repeats a vertex, the two steps just taken are inverses, because any longer return would be a simple cycle, and deleting that immediate reversal multiplies the product by \(1\) and shortens the walk. By induction the product equals \(1\), which is also its value at the trivial connection.
A simple closed walk of length 4 is a 4-cycle. U(1) transports commute, so the product depends on the orientation but not on the starting vertex. The trace meets each undirected 4-cycle in 4 starting vertices and two orientations. One orientation contributes \(e^{i\varphi _c}\) at each start, and the other contributes the conjugate. The 8 products sum to \(8\cos \varphi _c\). At the trivial connection they sum to \(8\). Subtracting these contributions gives the displayed identity.
Now let both periods \(N_1\) and \(N_2\) be integers at least \(4\), and let the vertices be residue classes in \(\mathbb Z/N_1\mathbb Z\times \mathbb Z/N_2\mathbb Z\), with an undirected edge from each vertex to its 4 axis neighbors. These neighbors are distinct, so the graph is simple. It is also triangle-free. A closed walk of length 3 would need net displacement zero in each coordinate. Each coordinate that returns to its start uses an even number of steps, so the whole walk would have even length, except if some coordinate is displaced by a nonzero multiple of its period. Three steps cannot make a displacement of size at least \(4\). The trace identity therefore applies.
A 4-cycle on this torus is 4 axis steps through 4 distinct vertices whose vector sum is zero in the torus. Write \(r\), \(l\), \(u\) and \(d\) for the numbers of steps in the 4 axis directions. If both periods are at least \(5\), each net displacement has absolute value at most \(4\) and is divisible by a period, so both nets vanish. Then \(r=l\), \(u=d\) and \(r+u=2\). Two steps out and back along one axis visit at most three vertices. The remaining case is one step in each direction. Any order in which a direction is followed immediately by its opposite repeats a vertex. The only remaining orders are the two cyclic orders around a unit square. Thus every 4-cycle is a plaquette, and \[\operatorname {Tr}L_U^4-\operatorname {Tr}L_1^4 =-8\sum _p(1-\cos \varphi _p),\] the sum running once over plaquettes.
If instead a period equals \(4\), 4 steps along that axis close after one winding and visit 4 distinct vertices. There is one such undirected cycle for each position in the transverse direction. A net displacement of size \(4\) uses all 4 steps, so these windings do not mix the two axes. They are 4-cycles, and they are not plaquettes. The same identity includes them, each with its own cosine, on the same footing as the plaquettes. For a holonomy in \(U(1)\), the sum \[-8\sum _p(1-\cos \varphi _p)\] is the Wilson face sum at coupling \(8\). The Wilson action is that shape of face sum for a finite group, with each plaquette weighted by \(1-\operatorname {Re}\chi _\rho (U_p)/d\). The trace identity has the same face sum, up to sign and coupling, precisely when every 4-cycle is a plaquette. The finite-group hypothesis of that note remains in force. A period equal to \(4\) adds winding cycles that a sum over plaquettes does not contain.
[marcolli2013gaugenetworks, Theorem 28] computes a different trace. On a four-dimensional square lattice, with cutoff inversely proportional to the spacing and with \(f(x)=x^4\), the spectral action equals minus one fourth of the two orientation traces around each plaquette, together with a constant and the Higgs terms displayed there.
[marcolli2013gaugenetworks, Proposition 29] states the corresponding continuum functional. This note does not reproduce those calculations. The operator here is the scalar Laplacian of the connection background, not their lattice Dirac operator.
The determinant action is \(\kappa \log \det Q_U\), where \(Q_U=L_U+m^2I\) and \(m>0\). For positive matrices this is \(\kappa \operatorname {Tr}\log Q_U\), a spectral action with \(f=\log \) applied to the massive precision rather than to \(L_U\). On a square torus with both periods at least 6, the induced plaquette coefficient isolates a length-4 plaquette sum in the large-mass expansion of that logarithm, for a real scalar and the sign representation. The logarithm is not the fourth-power trace proved above.
The comparison of these spectral actions remains speculative. Nothing proved here identifies \(\operatorname {Tr}\log Q_U\) with \(\operatorname {Tr}L_U^4\), or either finite trace with a continuum limit. The continuum statement in [marcolli2013gaugenetworks, Proposition 29] is their computation, and it is not a step in the identity for 4-cycles.
Ultrametric coarse-graining [fdip-0098]AGENTDRAFTED
- November 3, 2026
Ultrametric coarse-graining [fdip-0098]AGENTDRAFTED
- November 3, 2026
Can the law on a coarser grid be recovered exactly from the law on a finer grid?
Pair averages of a nearest-neighbour Gaussian on a path of 6 vertices are not nearest-neighbour: the two end blocks acquire a positive precision entry. The following section diagonalizes a precision built from nested residue classes. The next section takes up the means of those classes, and the last section remains speculative.
Theorem. Nested blocks diagonalize the hierarchical precision [fdip-0099]AGENTDRAFTED
- November 3, 2026
Theorem. Nested blocks diagonalize the hierarchical precision [fdip-0099]AGENTDRAFTED
- November 3, 2026
On the path with vertices \(0,1,2,3,4,5\), let \(\mu >0\) and let the precision be the path Laplacian plus \(\mu \) on the diagonal. The diagonal entries are \(\mu +1\) at the two ends and \(\mu +2\) at the 4 interior vertices, and each of the 5 edges contributes \(-1\). Write \(m_0,m_1,m_2\) for the averages of the three adjacent pairs and \(d_0,d_1,d_2\) for half the differences, so that the field on pair \(i\) is \(m_i+d_i\) and \(m_i-d_i\). The change from these coordinates, means before differences, to the path coordinates has constant Jacobian \(8\). In these coordinates the quadratic form has blocks \[\begin {aligned} H_{mm}&=\begin {pmatrix}2\mu +1&-1&0\\-1&2\mu +2&-1\\0&-1&2\mu +1\end {pmatrix},\\ B&=\begin {pmatrix}-1&-1&0\\1&0&-1\\0&1&1\end {pmatrix},\\ D&=\begin {pmatrix}2\mu +5&1&0\\1&2\mu +6&1\\0&1&2\mu +5\end {pmatrix}, \end {aligned}\] where \(B\) holds the cross terms between means and differences. The marginal precision of the three means is the Schur complement \(H_{mm}-BD^{-1}B^{T}\).
The corner of \(H_{mm}\) vanishes. The corner of \(BD^{-1}B^{T}\) is the pairing of \((-1,-1,0)\) with the solution of \(D(x,y,z)^{T}=(0,1,1)^{T}\). The first row gives \(y=-(2\mu +5)x\). The last row then gives \(z=x+1/(2\mu +5)\). Substitution in the middle row produces \[-2(\mu +2)(2\mu +7)x=\frac {2(\mu +2)}{2\mu +5},\] hence \(x=-1/((2\mu +5)(2\mu +7))\) and \(y=1/(2\mu +7)\). The pairing equals the corner of \(BD^{-1}B^{T}\): \[-x-y=-\frac {2(\mu +2)}{(2\mu +5)(2\mu +7)}.\] Subtracting it from the zero corner of \(H_{mm}\) gives the positive quantity \[\frac {2(\mu +2)}{(2\mu +5)(2\mu +7)}.\] A nearest-neighbour precision on the three coarse vertices would have a zero corner. These pair means do not.
Let \(p\ge 2\) and \(k\ge 1\) be integers, and let the sites be the residues modulo \(p^k\). For \(0\le j\le k\) let \(E_j\) replace the value at each site by the mean of the sites congruent to it modulo \(p^{k-j}\). Each such class has \(p^j\) sites. Thus \(E_0\) is the identity, since congruence modulo \(p^k\) isolates every residue, and \(E_k\) replaces every value by the mean of all the sites. Each \(E_j\) is symmetric, because its matrix is constant on the pairs inside each class and zero across classes, and \(E_j^2=E_j\), because a class mean is unchanged by a second average. If \(i\ge j\), congruence modulo \(p^{k-i}\) is coarser than congruence modulo \(p^{k-j}\), so each coarser class is a union of finer classes. A function constant on a coarser class is constant on each finer class inside it, and therefore \(E_jE_i=E_i\). That identity does not use the sizes of the classes. For the other order, every finer class has \(p^j\) sites, so the mean on a coarser class is the mean of the finer means and \(E_iE_j=E_i\).
In particular \(E_{j+1}E_j=E_jE_{j+1}=E_{j+1}\). Set \(P_j=E_j-E_{j+1}\) for \(j<k\), and \(P_k=E_k\). Then \(P_jE_{j+1}=E_jE_{j+1}-E_{j+1}^2=E_{j+1}-E_{j+1}=0\). If \(i>j\), then \(i\ge j+1\). The size-free identity gives \(E_{j+1}E_i=E_i\), so \(E_if=E_{j+1}(E_if)\) and the image of \(E_i\) lies in the image of \(E_{j+1}\). When \(i<k\) the same left factor gives \(E_{j+1}E_{i+1}=E_{i+1}\), and both summands of \(P_i\) land in that image. When \(i=k\), \(E_{j+1}E_k=E_k\). A vector in the image of \(P_i\) is therefore \(E_{j+1}\) applied to something, and \(P_jE_{j+1}=0\) gives \(P_jP_i=0\). Both matrices are symmetric, so the opposite product vanishes as well. The case \(P_k=E_k\) is symmetric and idempotent because \(E_k\) is. For \(j<k\), the square expands to \(E_j-E_jE_{j+1}-E_{j+1}E_j+E_{j+1}^2\), and the relations replace that by \(E_j-E_{j+1}-E_{j+1}+E_{j+1}=P_j\). Symmetry of \(P_j\) is the same property of the two averages. The sum of the projectors telescopes to \(E_0\), since \(E_0\) is the identity. These matrices are orthogonal projectors, they are pairwise orthogonal, and they sum to the identity. For real coefficients \(c_0,\ldots ,c_k\), the hierarchical precision \[Q=\sum _{j=0}^{k}c_jP_j\] acts on the image of \(P_j\) by multiplication by \(c_j\). Whenever every coefficient is nonzero, \(Q\) is invertible and its inverse multiplies that same image by \(c_j^{-1}\).
Theorem. Block means preserve the hierarchical precision [fdip-009A]AGENTDRAFTED
- November 3, 2026
Theorem. Block means preserve the hierarchical precision [fdip-009A]AGENTDRAFTED
- November 3, 2026
Let \(p\ge 2\) and \(k\ge 1\) be integers, and let the sites be the residues modulo \(p^k\). For \(0\le j\le k\), let \(E_j\) replace the value at each site by the mean of the sites congruent to it modulo \(p^{k-j}\). Each class has \(p^j\) sites, so \(E_0\) is the identity and \(E_k\) is the mean of every site. These are the averages of the nested blocks. Set \(P_j=E_j-E_{j+1}\) for \(j<k\) and \(P_k=E_k\). For nonzero real coefficients \(c_0,\ldots ,c_k\), the hierarchical precision \(Q=\sum _{j=0}^{k}c_jP_j\) is invertible.
Let \(A\) send a function \(\xi \) on these sites to the residues modulo \(p^{k-1}\) by the class means \[(A\xi )(r)=\frac {1}{p}\sum _{t=0}^{p-1}\xi (r+tp^{k-1}).\] The matrix \((AQ^{-1}A^{T})^{-1}\) equals the hierarchical precision \(Q'\) of depth \(k-1\) with coefficients \[c'_i=pc_{i+1}\qquad (0\le i\le k-1).\] If every \(c_j\) is positive, \(Q\) is the precision of a centered Gaussian law. In the counting basis, the second-moment matrix of \(A\xi \) is \((Q')^{-1}\).
Fix \(\lambda >0\) and a positive mass \(m\), and take \(c_j=\lambda ^j\) for \(j<k\) together with \(c_k=m\). Replacing \(A\xi \) by \(Z=\sqrt {p\lambda }\,A\xi \) divides the precision matrix \(Q'\) by \(p\lambda \). The resulting matrix is hierarchical of depth \(k-1\), with coefficient \(\lambda ^i\) on each projector below the top level and with top coefficient \(m/\lambda \). That top coefficient grows when \(0<\lambda <1\), stays unchanged when \(\lambda =1\), and shrinks when \(\lambda >1\). In the sense that a mass is relevant when it grows toward coarser scales, relevance holds only for \(0<\lambda <1\). The same coefficient relation repeats at every depth: the second-moment matrix of each block mean is the inverse of the coarser hierarchical precision. These matrix relations do not by themselves produce a Gaussian measure on functions on the \(p\)-adic integers.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Each \(E_j\) is symmetric, because its matrix is constant on the pairs inside a class and zero across classes, and \(E_j^2=E_j\), because a class mean is unchanged by a second average. If \(i\ge j\), congruence modulo \(p^{k-i}\) is coarser than congruence modulo \(p^{k-j}\), so each coarser class is a union of finer classes. A function constant on a coarser class is constant on each finer class inside it, and therefore \(E_jE_i=E_i\). That identity does not use the sizes of the classes. For the other order, every finer class has \(p^j\) sites, so the mean on a coarser class is the mean of the finer means and \(E_iE_j=E_i\).
In particular \(E_{j+1}E_j=E_jE_{j+1}=E_{j+1}\). Then \(P_jE_{j+1}=E_jE_{j+1}-E_{j+1}^2=E_{j+1}-E_{j+1}=0\). If \(i>j\), then \(i\ge j+1\). The size-free identity gives \(E_{j+1}E_i=E_i\), so \(E_if=E_{j+1}(E_if)\) and the image of \(E_i\) lies in the image of \(E_{j+1}\). When \(i<k\) the same left factor gives \(E_{j+1}E_{i+1}=E_{i+1}\), and both summands of \(P_i\) land in that image. When \(i=k\), \(E_{j+1}E_k=E_k\). A vector in the image of \(P_i\) is therefore \(E_{j+1}\) applied to something, and \(P_jE_{j+1}=0\) gives \(P_jP_i=0\). Both matrices are symmetric, so the opposite product vanishes as well. For \(j<k\) the square expands to \(E_j-E_jE_{j+1}-E_{j+1}E_j+E_{j+1}^2\), which equals \(E_j-E_{j+1}-E_{j+1}+E_{j+1}=P_j\). The case \(P_k=E_k\) is symmetric and idempotent because \(E_k\) is. The sum of the projectors telescopes to \(E_0\). Thus the \(P_j\) are pairwise orthogonal projectors summing to the identity, and \(Q\) multiplies the image of \(P_j\) by \(c_j\). Its inverse multiplies that image by \(c_j^{-1}\). The functions carry the counting inner product. Since \(P_j\) is symmetric and idempotent, \(\xi \cdot P_j\xi =|P_j\xi |^2\), and the quadratic form is \(\xi \cdot Q\xi =\sum _j c_j|P_j\xi |^2\). If \(\xi \neq 0\), some \(P_j\xi \) is nonzero because the projectors sum to the identity. Whenever every coefficient is positive, the form is therefore positive, and it is the precision of a centered Gaussian. By the inverse-precision theorem, that law has covariance operator \(Q^{-1}\). In the counting basis, the second-moment matrix of \(A\xi \) is \(AQ^{-1}A^{T}\).
Write \(S\) for the lift that makes a coarse function constant on each class: \((Sg)(r+tp^{k-1})=g(r)\). Averaging a constant returns the constant, so \(AS=I\). The counting pairing gives \((A^{T}g)\cdot \xi =g\cdot A\xi \), and the right-hand side expands to \[\sum _r g(r)\frac {1}{p}\sum _{t=0}^{p-1}\xi (r+tp^{k-1}).\] The coefficient of \(\xi (r+tp^{k-1})\) is \(g(r)/p\), so \(A^{T}=S/p\). The class mean is \((E_1\xi )(r+tp^{k-1})=(A\xi )(r)\). Averaging those \(p\) equal values returns \((A\xi )(r)\), hence \(AE_1=A\) and \(AP_0=0\).
For \(j\ge 1\), the coarse average \(E'_{j-1}\) is formed on the residues modulo \(p^{k-1}\) by classes congruent modulo \(p^{k-j}\). Fix a site \(x=r+tp^{k-1}\). Since \(j\ge 1\), the step \(p^{k-1}\) is divisible by \(p^{k-j}\), so the fine class of \(x\) modulo \(p^{k-j}\) consists of the sites \(r'+t'p^{k-1}\) whose coarse residue satisfies \(r'\equiv r\) modulo \(p^{k-j}\). Each such \(r'\) occurs for all \(p\) choices of \(t'\), and \(Sg\) depends only on \(r'\). The fine mean is therefore the coarse mean of \(g\), which is \((E'_{j-1}g)(r)=(SE'_{j-1}g)(x)\). Thus \(E_jS=SE'_{j-1}\). Applying \(A\) and using \(AS=I\) gives \(AE_jS=E'_{j-1}\), and \(AE_jA^{T}=E'_{j-1}/p\).
For \(1\le j\le k-1\) this difference is \(AP_jA^{T}=(E'_{j-1}-E'_j)/p\). The top term is \(AE_kA^{T}=E'_{k-1}/p\). Because \(AP_0=0\), \[AQ^{-1}A^{T}=\sum _{j=1}^{k}c_j^{-1}AP_jA^{T}.\] Reindex \(i=j-1\). The right-hand side equals \[\sum _{i=0}^{k-1}(pc_{i+1})^{-1}P'_i,\] where \(P'_i=E'_i-E'_{i+1}\) for \(i<k-1\) and \(P'_{k-1}=E'_{k-1}\). The same orthogonal decomposition on the coarser residues says that this sum is the inverse of the hierarchical precision \(Q'\) with coefficients \(c'_i=pc_{i+1}\). The matrix \(AQ^{-1}A^{T}\) is therefore invertible, and its inverse is \(Q'\). If the fine coefficients are positive, the coarse coefficients are positive as well.
Now take \(c_j=\lambda ^j\) for \(j<k\) and \(c_k=m\), with \(\lambda >0\) and \(m>0\). Then \(c'_i=p\lambda ^{i+1}\) for \(i<k-1\), while \(c'_{k-1}=pm\). Dividing \(Q'\) by \(p\lambda \) sends \(c'_i\) to \(\lambda ^i\) below the top level and sends the top coefficient to \(m/\lambda \). If \(Z\) denotes \(\sqrt {p\lambda }\,A\xi \), the second-moment matrix of \(Z\) is \(p\lambda \) times the second-moment matrix of \(A\xi \), so the second-moment matrix of \(Z\) is the inverse of \(Q'/(p\lambda )\). The top coefficient \(m/\lambda \) is larger than \(m\) when \(0<\lambda <1\), equal to \(m\) when \(\lambda =1\), and smaller than \(m\) when \(\lambda >1\).
Repeat the construction at every depth. If positive coefficients \(c^{(k)}_0,\ldots ,c^{(k)}_k\) satisfy \(c^{(k-1)}_i=pc^{(k)}_{i+1}\) for each \(i\), the second-moment matrix of the depth-\(k\) block mean is the inverse of the depth-\((k-1)\) hierarchical precision. The same matrix identity repeats at every depth. These identities do not by themselves produce a Gaussian measure on functions on the \(p\)-adic integers.
Theorem. Hierarchical Gaussians share a site fourth moment [fdip-009B]AGENTDRAFTED
- November 3, 2026
Theorem. Hierarchical Gaussians share a site fourth moment [fdip-009B]AGENTDRAFTED
- November 3, 2026
Let \(p\ge 2\) and \(k\ge 1\) be integers, and let the sites be the residues modulo \(p^k\). Let \(E_j\) and \(P_j\) be the nested averages and orthogonal projectors of the nested blocks, and let \(Q=\sum _{j=0}^{k}c_jP_j\) with every coefficient \(c_j\) positive. Then \(Q\) is a positive precision. In the counting basis its inverse has the same diagonal entry at every site, \[\sigma ^2=\sum _{j=0}^{k-1}c_j^{-1}\bigl (p^{-j}-p^{-(j+1)}\bigr ) +c_k^{-1}p^{-k}.\] The centered Gaussian law of \(Q\) gives every site the second moment \(\sigma ^2\), and the fourth moment at each site is \(3\sigma ^4\).
For distinct sites \(x\) and \(y\), let \(v\) be the largest integer such that \(x\equiv y\pmod {p^v}\). Then \(0\le v\le k-1\), and the matrix entry \(Q_{xy}\) depends only on \(v\).
The common value \(3\sigma ^4\) is the Gaussian moment of one quartic monomial. No non-Gaussian hierarchical fixed point is proved here. The paper of Abdesselam, Chandra and Guadagni, arXiv:1302.5971, has not been read, and this note does not state their result. Nothing proved here shows that the nearest-neighbour path precision, the finite Wilson action, or the fourth-power trace is a hierarchical precision on a residue ring.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Each class of \(E_j\) has \(p^j\) sites, and \(E_j\) replaces every value by the mean of its class. In the counting basis the matrix entry is \(p^{-j}\) when the two sites are congruent modulo \(p^{k-j}\), and zero otherwise. The diagonal entry is \(p^{-j}\) at every site. For \(j<k\) the diagonal of \(P_j=E_j-E_{j+1}\) is \(p^{-j}-p^{-(j+1)}\), and the diagonal of \(P_k=E_k\) is \(p^{-k}\).
The projectors are symmetric, pairwise orthogonal and sum to the identity. Symmetry gives \(h(v,P_jv)=h(P_jv,P_jv)\). Expanding \(v=\sum _i P_iv\) and using \(h(P_iv,P_jv)=h(v,P_iP_jv)=0\) for \(i\ne j\) gives \[h(v,v)=\sum _{j=0}^{k}h(P_jv,P_jv).\] The quadratic form is therefore \[h(v,Qv)=\sum _{j=0}^{k}c_j\,h(P_jv,P_jv).\] Each summand is nonnegative. If \(v\ne 0\), then \(h(v,v)>0\), so the form is at least the least coefficient times \(h(v,v)\) and is positive. Thus \(Q\) is a positive precision. The nested blocks give an inverse that multiplies the image of \(P_j\) by \(c_j^{-1}\), hence \(Q^{-1}=\sum _{j=0}^{k}c_j^{-1}P_j\). Every diagonal entry equals \(\sigma ^2\). The inverse-precision theorem converts that entry into the second moment of the coordinate.
Fix a site \(x\) and let \(X\) be the line through the counting basis vector \(\delta _x\). Retaining that line, the retained Gaussian marginal is the Gaussian law on \(X\) whose precision \(S\) satisfies \(h(\delta _x,S^{-1}\delta _x)=\sigma ^2\). The coordinate on \(X\) is the scalar \(t\) in \(t\delta _x\). Its law is the scalar Gaussian of precision \(a=1/\sigma ^2\).
Write \(g_a(t)=\exp (-at^2/2)\). The product rule gives \[(t^3g_a(t))'=3t^2g_a(t)-at^4g_a(t).\] Integration on \([-R,R]\) gives \[a\int _{-R}^{R}t^4g_a(t)\,dt =3\int _{-R}^{R}t^2g_a(t)\,dt -2R^3\exp (-aR^2/2).\] For \(u\ge 0\) the exponential series gives \(e^u\ge u^2/2\). At \(u=aR^2/2\) and \(R\ge 1\) the boundary term is at most \(16/(a^2R)\), so it tends to zero. The integrands are nonnegative, and polynomial moments make their full integrals finite, so the compact integrals increase to those limits. Therefore \[a\int _{\mathbb R}t^4g_a(t)\,dt =3\int _{\mathbb R}t^2g_a(t)\,dt.\] The scalar Gaussian integral is \(I(a)\). Dividing by it and using the scalar identity \(\int t^2g_a=I(a)/a\) from the inverse-precision theorem gives the normalized moment \(3/a^2=3\sigma ^4\). The polynomial pullback in Theorem [fdip-000E] carries this moment to the coordinate \(\phi (x)\).
If \(x\ne y\), the integer \(v\) above is the largest for which the two sites are congruent modulo \(p^v\), and \(v\le k-1\) because the sites are distinct residues modulo \(p^k\). Congruence modulo \(p^{k-j}\) holds exactly when \(k-j\le v\). The matrix entry of \(E_j\) at this pair is therefore determined by \(v\). The same is true of every \(P_j\), and of \(Q\).
Gluing and spin networks [fdip-009C]AGENTDRAFTED
- November 3, 2026
Gluing and spin networks [fdip-009C]AGENTDRAFTED
- November 3, 2026
Can the physics on a closed surface be built by joining the physics of its pieces?
Attaching a handle composes boundary counts by convolution of class functions. The closed count is the value of that convolution at the identity. The normalized flat partition function of a cellulation of genus \(g\) is that value divided by \(|G|^{2g-1}\). On a finite graph, invariant tensors at the vertices span the gauge-invariant functions, and the dimension of those functions is the number of gauge orbits.
The papers that present finite-group gauge theory as the two-dimensional theory of the center of the group algebra have not been read. This chapter does not identify the handle convolution with that theory or with the spatial transfer operator. No continuous spin-network basis is claimed.
Theorem. Handle convolution computes the homomorphism count [fdip-00A8]AGENTDRAFTED
- November 3, 2026
Theorem. Handle convolution computes the homomorphism count [fdip-00A8]AGENTDRAFTED
- November 3, 2026
Let \(G\) be a finite group, and choose one unitary representative of each irreducible complex representation, as in the surface data. Write \(d_\rho \) for its dimension and \(\chi _\rho \) for its character. For an integer \(g\ge 0\), let \(\Pi _g\) be the group presented by generators \(x_1,y_1,\ldots ,x_g,y_g\) and the single relation that the product of the commutators \(x_iy_ix_i^{-1}y_i^{-1}\) is the identity. The case \(g=0\) is the trivial group. Write a commutator as \([a,b]=aba^{-1}b^{-1}\), and write \((\psi *\phi )(h)\) for the convolution \(\sum _{x\in G}\psi (x)\phi (x^{-1}h)\). Let \(\psi _g(h)\) be the number of \(2g\)-tuples in \(G\) whose product of commutators equals \(h\), with the empty product equal to the identity. Then each \(\psi _g\) is a class function, \(\psi _{g+1}=\psi _g*\psi _1\), and \[\psi _g(h)=\sum _{\rho \in \widehat G}|G|^{2g-1}d_\rho ^{1-2g}\chi _\rho (h).\] The number of homomorphisms satisfies \[\frac {|\operatorname {Hom}(\Pi _g,G)|}{|G|} =\sum _{\rho \in \widehat G} \left (\frac {|G|}{d_\rho }\right )^{2g-2}.\]
Let \(f\) be the class function with \(f(1)=|G|\) and with value \(0\) at every other group element. For every surface admitted by the finite surface character formula, including the exceptional one-vertex sphere, \[Z_\Sigma (f)=\frac {\psi _g(1)}{|G|^{2g-1}}.\] Thus the normalized flat partition function depends on the cellulation only through the genus, and it is the identity value of the \(g\)-fold handle convolution divided by \(|G|^{2g-1}\).
Attaching one handle is convolution with \(\psi _1\), and closing the remaining boundary is evaluation at the identity. The papers that identify this composition with the two-dimensional theory of the center of the group algebra have not been read, and this note does not state their result. Nothing proved here identifies the pure-gauge transfer operator with this convolution.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
If \(\prod _i[a_i,b_i]=h\), replacing every entry by its conjugate by a fixed element replaces the product by the conjugate of \(h\). That replacement is a bijection of tuples, so \(\psi _g\) is a class function. Splitting off the last commutator gives \(\psi _{g+1}(h)=\sum _x\psi _g(x)\psi _1(x^{-1}h)\) for \(g\ge 0\). The identity \(\psi _0(h)=1\) when \(h=1\), and \(0\) otherwise, is the empty tuple.
The matrix orthogonality in Theorem [fdip-006W] says \[\frac 1{|G|}\sum _{h\in G} \rho (h)_{ij}\tau (h^{-1})_{ab} =\begin {cases} d_\rho ^{-1}\delta _{ib}\delta _{ja},&\rho =\tau ,\\ 0,&\rho \ne \tau . \end {cases}\] Unitarity gives \(\tau (h^{-1})_{ab}=\overline {\tau (h)_{ba}}\). Relabelling the indices therefore gives \[\frac 1{|G|}\sum _{h\in G} \rho (h)_{ij}\overline {\tau (h)_{kl}} =\begin {cases} d_\rho ^{-1}\delta _{ik}\delta _{jl},&\rho =\tau ,\\ 0,&\rho \ne \tau . \end {cases}\] Sum \(\rho (h)_{ii}\overline {\tau (h)_{kk}}\) over the diagonal indices \(i\) and \(k\). The identity supplies a factor \(d_\rho ^{-1}\) only when \(i=k\), and there are \(d_\rho \) such indices, so \[\frac 1{|G|}\sum _{h\in G} \chi _\rho (h)\overline {\chi _\tau (h)}=\begin {cases} 1,&\rho =\tau ,\\ 0,&\rho \ne \tau . \end {cases}\] In particular \(\sum _h|\chi _\rho (h)|^2=|G|\). The trace of the unitary identity \(\tau (h^{-1})=\tau (h)^*\) gives \(\chi _\tau (h^{-1})=\overline {\chi _\tau (h)}\).
Let \(f(h)=\sum _\rho d_\rho \chi _\rho (h)\). The character expansion gives \(f\) the coefficient \[c_\tau =\frac 1{|G|}\sum _h f(h)\overline {\chi _\tau (h)}=d_\tau \] against \(\chi _\tau \). The class function \(|G|\) at the identity and \(0\) elsewhere has the same coefficients, so \(\sum _\rho d_\rho \chi _\rho (h)\) equals \(|G|\) at the identity and equals \(0\) elsewhere. Thus \(\psi _0=\sum _\rho (d_\rho \,|G|^{-1})\chi _\rho \), and evaluating at the identity gives \(\sum _\rho d_\rho ^2=|G|\).
For a linear map \(A\) on the space of \(\rho \), the average \[S(A)=\frac 1{|G|}\sum _{g\in G}\rho (g)A\rho (g)^{-1}\] commutes with every \(\rho (h)\). Over \(\mathbb C\) the endomorphism \(S(A)\) has an eigenvalue. Its eigenspace is invariant, and irreducibility forces the eigenspace to be the whole space, so \(S(A)\) is scalar. Its trace equals \(\operatorname {tr}A\), hence \(S(A)=(\operatorname {tr}A/d_\rho )I\). Taking \(A=\rho (b)\) gives \[\sum _{a\in G}\rho (a)\rho (b)\rho (a)^{-1} =\frac {|G|}{d_\rho }\chi _\rho (b)\,I.\] Multiply by \(\rho (b)^{-1}\) and sum over \(b\). The left side is \(\sum _{a,b}\rho ([a,b])\). The right side is \((|G|/d_\rho )\sum _b\chi _\rho (b)\rho (b)^{-1}\).
Set \(C=\sum _b\overline {\chi _\rho (b)}\rho (b)\). Then \(\rho (h)C\rho (h)^{-1}=C\), because \(\chi _\rho \) is a class function, so the same scalar argument gives \(C=(|G|/d_\rho )I\). The trace computation uses \(\sum _b|\chi _\rho (b)|^2=|G|\). The change of variable \(b\mapsto b^{-1}\) and \(\chi _\rho (b)=\overline {\chi _\rho (b^{-1})}\) identify \(\sum _b\chi _\rho (b)\rho (b)^{-1}\) with \(C\). Therefore \[\sum _{a,b\in G}\rho ([a,b]) =\left (\frac {|G|}{d_\rho }\right )^2 I.\] Taking traces gives \(\sum _{a,b}\chi _\rho ([a,b])=|G|^2/d_\rho \). Inverting a commutator swaps the two summation variables, so the same sum with \(\overline {\chi _\rho }\) is equal. The coefficient in the character expansion is that sum divided by \(|G|\), hence \(|G|/d_\rho \): \[\psi _1=\sum _{\rho \in \widehat G} \frac {|G|}{d_\rho }\chi _\rho .\]
Expand the character convolution and insert a matrix product for the second character: \[(\chi _\rho *\chi _\tau )(z) =\sum _x\sum _{i,k,l} \rho (x)_{ii}\tau (x^{-1})_{kl}\tau (z)_{lk}.\] The matrix identity already displayed sums the variable \(x\): the sum over \(x\) of \(\rho (x)_{ii}\tau (x^{-1})_{kl}\) equals \(|G|d_\rho ^{-1}\) when \(\rho =\tau \), \(i=l\) and \(i=k\), and equals zero otherwise. Multiplying by \(\tau (z)_{lk}\) and summing those indices leaves the trace of \(\tau (z)\), so \[(\chi _\rho *\chi _\tau )(z) =\begin {cases} (|G|/d_\rho )\chi _\rho (z),&\rho =\tau ,\\ 0,&\rho \ne \tau . \end {cases}\] Consequently, if \(\alpha _\rho \) and \(\beta _\rho \) are the character coefficients of two class functions, the coefficient of \(\chi _\rho \) in their convolution is \(\alpha _\rho \beta _\rho (|G|/d_\rho )\). Convolution against \(\psi _1\) multiplies the coefficient \(\alpha _\rho \) by \(|G|^2/d_\rho ^2\). Starting from \(\psi _0\) and applying this multiplication \(g\) times gives the displayed formula for \(\psi _g\).
A homomorphism \({\Pi _g}\to G\) is exactly a \(2g\)-tuple whose product of commutators is the identity, so \(|\operatorname {Hom}(\Pi _g,G)|=\psi _g(1)\). The displayed expansion at the identity is \(|G|^{2g-1}\sum _\rho d_\rho ^{2-2g}\). Dividing by \(|G|\) gives the homomorphism formula.
For the stated face weight, the character expansion in Definition [fdip-006V] has \(c_\rho =d_\rho \). Every ratio \(c_\rho/d_\rho \) equals \(1\), so Theorem [fdip-006W] gives \(Z_\Sigma (f)=\sum _\rho d_\rho ^{2-2g}\). The evaluation of \(\psi _g\) at the identity is \(|G|^{2g-1}\) times that sum.
Theorem. Invariant tensors count the gauge orbits [fdip-00A9]AGENTDRAFTED
- November 3, 2026
Theorem. Invariant tensors count the gauge orbits [fdip-00A9]AGENTDRAFTED
- November 3, 2026
Let \(G\) be a finite group, with unitary irreducible representatives as in the surface data. Let \(s,h:E\to V\) be a finite incidence presentation; loops and parallel edges are allowed, and either set may be empty. The gauge action of \(G^V\) on connections \(U\in G^E\) is \[(g\cdot U)_e=g_{h(e)}U_eg_{s(e)}^{-1}.\] A function \(F:G^E\to \mathbb C\) is gauge invariant when \(F(g\cdot U)=F(U)\) for every \(g\). The dimension of the gauge-invariant functions equals the number of orbits of this action. It also equals \[\sum _{\rho }\prod _{x\in V}\dim W_x(\rho )^G,\] where the sum runs over all assignments of irreducible representatives to the edges. For each assignment, the local space at a vertex \(x\) is the tensor product of the representation spaces of the edges leaving \(x\) and of the dual spaces of the edges entering \(x\). An empty tensor product is the scalar line. The group element \(g_x\) acts by \(\rho _e(g_x)^{-1}\) on each outgoing factor and by \((\,g_x\cdot \lambda )(v)=\lambda (\rho _e(g_x)v)\) on each incoming covector. A basis of the invariant tensors in these local spaces, as the edge assignment varies, pushes to a basis of the gauge-invariant functions.
The datum of an edge assignment together with one invariant tensor at each vertex is the finite spin-network datum of this note. Nothing proved here identifies that datum with a continuous orthonormal basis, or with the charged multiplicity spaces.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Two connections lie in the same orbit exactly when one is the image of the other under \(G^V\). A gauge-invariant function is constant on each orbit, and the indicator of an orbit is gauge invariant. Those indicators are linearly independent and span the invariant functions, so the dimension equals the number of orbits.
The identity \(\sum _\rho d_\rho ^2=|G|\) is the evaluation at the identity in the handle convolution. The matrix orthogonality derived there makes the \(|G|\) matrix coefficients of the irreducible representatives linearly independent as functions on \(G\). They are therefore a basis of all functions on \(G\). Products of basis functions, one factor for each edge, are a basis of the functions on \(G^E\). Grouping that basis by the edge assignment writes every function uniquely as a sum of its assignment components. The gauge action preserves each component. On an edge it multiplies on the left by the element at the head and on the right by the inverse of the element at the source, and that two-sided action keeps the value in the matrix-coefficient span of the same representation.
Fix an edge assignment \(\rho \). Send an elementary tensor \(\bigotimes _e(v_e\otimes \lambda _e)\) to the function \[F(U)=\prod _{e\in E}\lambda _e(\rho _e(U_e)v_e),\] and extend linearly. On basis vectors this produces every product of matrix coefficients of the assigned representations, so the map is an isomorphism from \(\bigotimes _e(V_e\otimes V_e^*)\) onto the assignment component. Substituting the gauge action gives \[F(g\cdot U) =\prod _e\lambda _e\bigl (\rho _e(g_{h(e)}) \rho _e(U_e)\rho _e(g_{s(e)})^{-1}v_e\bigr ).\] The right-hand side is the function of the tensor whose vector at \(e\) is \(\rho _e(g_{s(e)})^{-1}v_e\) and whose covector at \(e\) is \(g_{h(e)}\cdot \lambda _e\). Reordering tensor factors assigns each vector factor to the source vertex and each covector factor to the head vertex. Under that reordering the isomorphism is equivariant for \(G^V\), and the action of \(g_x\) touches only the factors assigned to \(x\).
Averaging over the group element at one vertex is a projector onto the tensors fixed by that vertex, and it acts on the factor belonging to that vertex. The average over \(G^V\) is the composition of these commuting projectors, so its image is the tensor product of the local invariant spaces. The dimension of the invariant tensors in one assignment is therefore the product of the local invariant dimensions. A function is gauge invariant exactly when every assignment component comes from an invariant tensor. Summing the dimensions gives the stated count, and bases of the local invariant spaces push to a basis of the gauge-invariant functions.
Contexts and background stacks [fdip-009D]AGENTDRAFTED
- November 3, 2026
Contexts and background stacks [fdip-009D]AGENTDRAFTED
- November 3, 2026
Which families of observables admit a joint classical value?
A context is a commutative unital *-subalgebra of a matrix algebra. A global point assigns a character to every context in a family, and the assigned characters agree on shared elements. The following section shows that 6 contexts cut out by one square in \(M_4(\mathbb C)\) have no global point, while each context separately does. Whether this obstruction organises the selectors remains open. The last section remains speculative.
Theorem. One square of contexts has no global point [fdip-009E]AGENTDRAFTED
- November 3, 2026
Theorem. One square of contexts has no global point [fdip-009E]AGENTDRAFTED
- November 3, 2026
A context in \(M_n(\mathbb C)\) is a unital commutative *-subalgebra. A character of a context is a unital *-homomorphism from that algebra to \(\mathbb C\). For a finite family of contexts, a global point is a choice of one character of each context such that the chosen characters agree on every matrix that lies in two of them. Such a point exists if and only if there is a function on the union of the contexts whose restriction to each context is a character. This equivalence is the Kochen-Specker formulation for a finite family.
Let \(\sigma _1,\sigma _2,\sigma _3\) be the Pauli matrices, and let \(I\) be the \(2\times 2\) identity. In \(M_4(\mathbb C)\), the 9 Kronecker products \[\begin {array}{ccc} \sigma _1\otimes I & I\otimes \sigma _1 & \sigma _1\otimes \sigma _1\\ I\otimes \sigma _2 & \sigma _2\otimes I & \sigma _2\otimes \sigma _2\\ \sigma _1\otimes \sigma _2 & \sigma _2\otimes \sigma _1 & \sigma _3\otimes \sigma _3 \end {array}\] are Hermitian involutions. Matrices in one row commute, and matrices in one column commute. The product of each row, in the displayed order, is the \(4\times 4\) identity \(I\otimes I\). The three column products are \(I\otimes I\), \(I\otimes I\) and \(-I\otimes I\). The unital *-algebras generated by the three rows and the three columns are 6 contexts. That family has no global point. Each of the 6 contexts does have a character.
The equivalence does not show that the family of every commutative subalgebra of \(M_n(\mathbb C)\) has no global point. Nothing proved here identifies a context with a selector. Whether global points of this kind organise those selectors remains open. The accounts of Mermin, Peres, Heunen, Landsman and Spitters, and Doering and Isham are not premises of the multiplication.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
The two conditions are equivalent. From a global point, define a function by evaluating the character of any chosen context that contains the matrix. Agreement on shared matrices makes the value independent of the choice, and the restriction to each context is the chosen character. Conversely, the restrictions of such a function are characters, and they agree on shared matrices.
On an elementary tensor, \((A\otimes B)(e_j\otimes f_l)=Ae_j\otimes Bf_l\). Extending that rule by linearity and applying it twice gives \((A\otimes B)(C\otimes D)=(AC)\otimes (BD)\). The matrix entry of \(A\otimes B\) from \(e_j\otimes f_l\) to \(e_i\otimes f_k\) is \(A_{ij}B_{kl}\). The adjoint entry, placed from \(e_i\otimes f_k\) back to \(e_j\otimes f_l\), is the conjugate \(\overline {A_{ij}B_{kl}}=A^*_{ji}B^*_{lk}\), which is the matching entry of \(A^*\otimes B^*\). Thus \((A\otimes B)^*=A^*\otimes B^*\).
The Pauli matrices are Hermitian and square to \(I\). Multiplying the matrices gives \[\begin {aligned} \sigma _1\sigma _2&= \begin {pmatrix}0&1\\1&0\end {pmatrix} \begin {pmatrix}0&-i\\i&0\end {pmatrix} =\begin {pmatrix}i&0\\0&-i\end {pmatrix}=i\sigma _3,\\ \sigma _2\sigma _3&= \begin {pmatrix}0&-i\\i&0\end {pmatrix} \begin {pmatrix}1&0\\0&-1\end {pmatrix} =\begin {pmatrix}0&i\\i&0\end {pmatrix}=i\sigma _1,\\ \sigma _3\sigma _1&= \begin {pmatrix}1&0\\0&-1\end {pmatrix} \begin {pmatrix}0&1\\1&0\end {pmatrix} =\begin {pmatrix}0&1\\-1&0\end {pmatrix}=i\sigma _2. \end {aligned}\] Since the factors are Hermitian, \((\sigma _1\sigma _2)^*=\sigma _2\sigma _1\) and \((i\sigma _3)^*=-i\sigma _3\), so \(\sigma _2\sigma _1=-i\sigma _3\). The same adjoint step reverses the other two products. Distinct Pauli matrices therefore anticommute.
Each of the 9 Kronecker products is Hermitian, and its square is \(I\otimes I\). If the left factors commute and the right factors commute, the two orders of the Kronecker product agree. The identity commutes with every matrix, and every matrix commutes with itself, so this covers every pair in the first two rows and the first two columns. In the third row, and throughout the third column, each pair is a Kronecker product of two distinct Pauli matrices on the left and two distinct Pauli matrices on the right. Both sides anticommute, and the two signs cancel, so those tensors commute as well.
The row products are \[\begin {aligned} (\sigma _1\otimes I)(I\otimes \sigma _1)(\sigma _1\otimes \sigma _1) &=(\sigma _1\otimes \sigma _1)^2=I\otimes I,\\ (I\otimes \sigma _2)(\sigma _2\otimes I)(\sigma _2\otimes \sigma _2) &=(\sigma _2\otimes \sigma _2)^2=I\otimes I,\\ (\sigma _1\otimes \sigma _2)(\sigma _2\otimes \sigma _1) (\sigma _3\otimes \sigma _3) &=(i\sigma _3\otimes (-i\sigma _3))(\sigma _3\otimes \sigma _3) =I\otimes I. \end {aligned}\] The column products are \[\begin {aligned} (\sigma _1\otimes I)(I\otimes \sigma _2)(\sigma _1\otimes \sigma _2) &=(\sigma _1\otimes \sigma _2)^2=I\otimes I,\\ (I\otimes \sigma _1)(\sigma _2\otimes I)(\sigma _2\otimes \sigma _1) &=(\sigma _2\otimes \sigma _1)^2=I\otimes I,\\ (\sigma _1\otimes \sigma _1)(\sigma _2\otimes \sigma _2) (\sigma _3\otimes \sigma _3) &=(i\sigma _3\otimes i\sigma _3)(\sigma _3\otimes \sigma _3) =-(I\otimes I). \end {aligned}\] Within a row or a column the three matrices commute. If \((AB)C=I\otimes I\) and \(C^2=I\otimes I\), then \(AB=(AB)C^2=((AB)C)C=C\). If instead \((AB)C=-(I\otimes I)\), then \(AB=(AB)C^2=((AB)C)C=(-(I\otimes I))C=-C\). The first case is every row and the first two columns. The second case is the third column.
A character sends a Hermitian involution to a complex number \(t\) with \(t^2=1\), hence to \(\pm 1\), and it sends a product of commuting elements to the product of the values. The three values on a row therefore multiply to \(+1\). The three column products force the values \(+1\), \(+1\) and \(-1\). The product of the three row constraints equals the product of all 9 values and equals \(+1\). The product of the three column constraints is the same product of 9 values and equals \(-1\). No choice of signs satisfies both. A global point would supply such signs, so the 6 contexts have no global point.
Each context separately has a character. The trace multiplies over a Kronecker product, \(\operatorname {Tr}(A\otimes B)=\operatorname {Tr}(A)\operatorname {Tr}(B)\), because the diagonal entries are \(A_{ii}B_{kk}\). Thus \(\operatorname {Tr}\bigl ((\sigma _a\otimes \sigma _b)(\sigma _c\otimes \sigma _d)\bigr ) =\operatorname {Tr}(\sigma _a\sigma _c)\operatorname {Tr}(\sigma _b\sigma _d)\), where \(\sigma _0\) means \(I\). The square of each of these 4 matrices is \(I\), so its trace against itself is \(\operatorname {Tr}(I)=2\). Each displayed product \(i\sigma _k\) has trace zero, so each \(\sigma _k\) has trace zero. The product of two distinct matrices among the 4 is either one of them or \(\pm i\) times one of them, and in every case the trace is zero. Distinct tensors \(\sigma _a\otimes \sigma _b\) are therefore orthogonal for \(\operatorname {Tr}(P^*Q)\). The square of such a tensor is \(I\otimes I\), so \(\operatorname {Tr}(P^*P)=4\). The 4 matrices of any one row or column are the identity tensor together with three generators. They are 4 distinct tensors of this form, each with nonzero trace against itself, so they are linearly independent.
Write \(A\) and \(B\) for the first two matrices of a context and \(C\) for the third. They commute. Assign \(\pm 1\) freely to \(A\) and \(B\). Where \(AB=C\), set the value of \(C\) equal to the product of the other two values. Then \(AC=A(AB)=B\) and \(BC=B(AB)=A\), and the values match. Where \(AB=-C\), which is the third column, set the value of \(C\) equal to the opposite of that product. Then \(AC=A(-AB)=-B\). Since \(A\) and \(B\) commute, \(BC=B(-AB)=-A\). Each value carries the same minus sign. Every square equals \(I\otimes I\) and has value \(+1\). Opposite orders agree because the matrices commute and the values commute. These 4 matrices therefore span the algebra they generate, and the linear extension of the assignment is a unital algebra homomorphism on that basis. Every basis matrix is Hermitian and every value is real, so the extension preserves the *-operation.
Theorem. Background symmetries form a presheaf of groupoids [fdip-009F]AGENTDRAFTED
- November 3, 2026
Theorem. Background symmetries form a presheaf of groupoids [fdip-009F]AGENTDRAFTED
- November 3, 2026
Let a group \(G\) act on the left on a set \(X\). For each subgroup \(H\), the action groupoid \(H\ltimes X\) has the elements of \(X\) as objects, and an arrow \(h:x\to y\) for each \(h\in H\) with \(h\cdot x=y\). If \(H\) is contained in a subgroup \(K\), sending each arrow to itself is a functor \(H\ltimes X\to K\ltimes X\), identical on objects. These functors preserve identities and composition, and they compose with the inclusions of subgroups. The assignment is therefore a functor from the poset of subgroups of \(G\) to groupoids. Equivalently, it is a groupoid-valued presheaf on the opposite of that poset.
The isomorphism classes of \(H\ltimes X\) are the orbits of \(H\). Thus the objects modulo the symmetries in \(H\) are the isomorphism classes of that groupoid. The enriched four-cycle backgrounds carry an action of the dihedral group constructed there. The action groupoid in that note is the value of this presheaf at that whole group. That note is transcluded by enriched backgrounds. The reader guide places that comparison in Part V, with the Clifford algebras and the Dirac operators. The chapter on backgrounds and symmetry does not transclude the four-cycle note or the enriched-backgrounds note. It says that its examples prepare those comparisons. The arrow pattern is the action groupoid. This note does not claim that every background in that chapter arises from the four-cycle.
No stack is proved. A stack would require a topology and a descent equivalence for compatible families. No cover is defined here, and no descent map is shown to be an equivalence. The finite tests of where the topos layer begins record that the action-groupoid example does not require a quotient stack, and that those tests have supplied no site, descent theorem, or physical correspondence. Whether this presheaf organises a stack of backgrounds remains open.
Proof.
- November 3, 2026
Proof.
- November 3, 2026
Composition in \(H\ltimes X\) sends \(g:x\to y\) and \(k:y\to z\) to \(kg:x\to z\). The action law gives \((kg)\cdot x=k\cdot (g\cdot x)\), so the composite is an arrow. The identity arrow is \(1:x\to x\). The inverse of \(h:x\to h\cdot x\) is \(h^{-1}:h\cdot x\to x\), and \(h^{-1}\) lies in \(H\) because \(H\) is a subgroup. The two inverse identities and associativity are the corresponding group laws. Every arrow is therefore invertible.
Suppose \(H\subset K\). An arrow labelled by an element of \(H\) is an arrow of \(K\ltimes X\) with the same source and target. The identity element and the product \(kg\) are unchanged by this inclusion, so the map on arrows preserves identities and composition. If \(H\subset K\subset L\), the composite of the two inclusions of arrows is the inclusion of \(H\) into \(L\). The inclusion of a subgroup into itself is the identity functor. This is a functor from the subgroup poset to groupoids. That poset has one morphism from \(H\) to \(K\) exactly when \(H\) is contained in \(K\), and the functor sends it to the inclusion of action groupoids. A groupoid-valued presheaf on a category is a functor from the opposite of that category. The opposite of the opposite of the subgroup poset is the subgroup poset, so the functor just constructed is a groupoid-valued presheaf on the opposite poset.
Two objects are isomorphic exactly when some element of \(H\) carries one to the other, which is the definition of an orbit. For the dihedral action, the groupoid at the whole group is the one whose arrows are already identified in the enriched four-cycle note. No topology on the subgroup poset is defined, so the presheaf is not given the data of a stack.
The compatibility test as a definition [fdip-009Y]AGENTDRAFTED
- November 2, 2026
The compatibility test as a definition [fdip-009Y]AGENTDRAFTED
- November 2, 2026
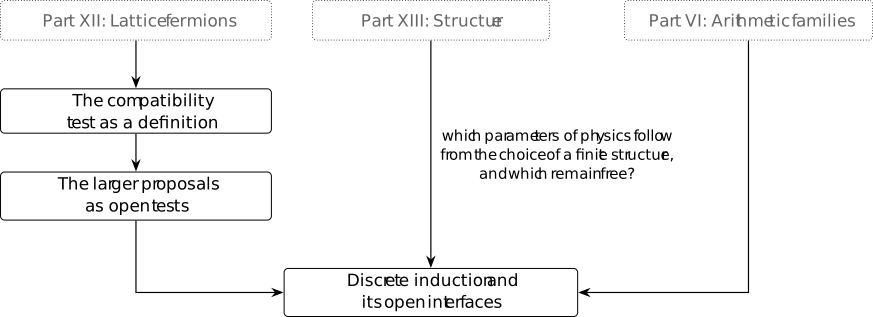
Which declared group, representation, selector and comparison fit together, and which proposed correspondences are still missing? A finite symmetry can act on a spinor, on a rotation space, or on values at the vertices. Those actions are different data.
The test uses the representation datum, the binary tetrahedral quotient and its two fibers, the central idempotent of the real group algebra of \(2T\), and the separation of spinor and internal factors in the covariant Dirac operator. The identities proved here do not use the structure questions.
A compatibility datum names the group, the coefficient field, the representation, the action on the finite graph, the selector and one reference comparison. Then 5 criteria say what has been proved, what is only conditional, and what is open. The worked case is the binary tetrahedral spinor. Correspondences for the larger classical groups are not constructed. They are recorded as open tests.
Definition. A five-part compatibility datum [fdip-009Z]AGENTDRAFTED
- November 2, 2026
Definition. A five-part compatibility datum [fdip-009Z]AGENTDRAFTED
- November 2, 2026
A compatibility datum is a tuple \[(G,\mathbb K,\rho ,\alpha ,\sigma ,C).\] Here \(G\) is a group, \(\mathbb K\in \{\mathbb R,\mathbb C\}\) is its coefficient field, and \(\rho :G\to GL_{\mathbb K}(F)\) is a finite-dimensional representation on a fiber \(F\). The map \(\alpha \) is an action of \(G\) on a finite graph substrate, in the sense of a representation datum. The selector \(\sigma \) is an idempotent in a declared algebra of operators on \(F\), or on a finite direct sum of such fibers. The reference comparison \(C\) is a stated homomorphism, quotient, or numerical identification against one named object. The coefficient field is scalar data for \(F\). It is not a residual gauge group. When \(\mathbb K=\mathbb R\), a complex representation enters only after realification, as a real representation on the underlying real vector space. A direct sum of that real fiber with another real fiber is then one real representation.
The datum is tested against 5 criteria.
- Exactness. The group, the field, the representation and the substrate action are all specified. An inclusion into a matrix group is not a substitute for the missing slot.
- Declared maps. Each comparison with a Dirac, Lorentz, gauge or gravitational structure names the homomorphism, kernel, cover or branching rule that is actually used.
- Separation. A spinor or Dirac action is identified with a gravitational action only when a separate compatibility law is proved. Sharing a name, or an inclusion into \(SU(2)\), is not that law.
- Selector effect. The selector is given, and there is a proof of the change it makes to the operator or parameter named in the datum.
- Reference recovery. The comparison names the ordinary object recovered in the chosen reference sector, or it records that the datum claims no such recovery.
For a fixed datum, each criterion is marked proved, conditional or open. Proved means the finite obligation stated in that criterion is established. Conditional means a stated part is established and the complementary part is unresolved. Open means the required map or recovery is not constructed. An open mark records that absence. It is not a theorem that no later construction exists.
Proposition. Finite identities for the binary tetrahedral spinor [fdip-00A0]AGENTDRAFTED
- November 2, 2026
Proposition. Finite identities for the binary tetrahedral spinor [fdip-00A0]AGENTDRAFTED
- November 2, 2026
Let \(2T\) be the group of 24 Hurwitz units in the binary tetrahedral quotient. In this model the central group element is the quaternion \(-1\). The distinguished central involution of the abstract group is the preimage of that quaternion under the comparison isomorphism, not the quaternion itself. Let \(\pi :SU(2)\to SO(3)\) be the conjugation homomorphism of Proposition [fdip-007G], and write \(R_T=\pi (2T)\). Let \(\rho _s\) be the defining representation on \(\mathbb C^2\) through the matrix map \(M\) of the same statement, and let \(\tau \) be the three-dimensional representation on \(\operatorname {span}_{\mathbb R}\{i,j,k\}\) given by \(\tau (q)v=qvq^{-1}\). Both are the fibers of the two-fiber example. The substrate action \(\alpha \) is trivial. On the sum \(F=\mathbb C^2\oplus \mathbb R^3\), with \(\rho =\rho _s\oplus \tau \), the selector \(\sigma \) of the compatibility datum is the idempotent \[P=\frac {I-\rho (-1)}2.\] The abstract involution \(z\) maps to the quaternion \(-1\), so \(P\) is the image of the central idempotent \(e_-=(1_A-[z])/2\) under \(\rho \). That idempotent is the one in the real group algebra. The reference comparison \(C\) is the pair of homomorphisms \(\pi :SU(2)\to SO(3)\) and the vertex identification \(R_T\cong A_4\) proved below.
Then \(\ker (\pi |_{2T})=\{1,-1\}\), the vertex action induces \(R_T\cong A_4\), and \[P=I_2\oplus 0.\] Left multiplication by the quaternion \(-1\) is \(-1\) on the quaternion module, so that module is fixed by \(e_-\) and annihilated by \(e_+=(1_A+[z])/2\). The products of the \(d=3\) Clifford matrices of the spatial Dirac operator reproduce the quaternion multiplication table. None of these identities supplies a covariance law for that Dirac operator.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
The kernel statement is the restriction of \(\ker \pi =\{1,-1\}\) from Proposition [fdip-007G]. The same source identifies \(2T\) with the full preimage \(\pi ^{-1}(R_T)\) and gives \(|R_T|=12\). The matrix \(M(-1)=-I_2\), so \(\rho _s(-1)=-I_2\). Conjugation by the quaternion \(-1\) is the identity, so \(\tau (-1)=I_3\). Therefore \[P=I_2\oplus 0.\] On the quaternion module, left multiplication by the quaternion \(-1\) is \(-1\), so that module's algebra action sends \(e_-\) to \(1\) and \(e_+\) to \(0\). The abstract involution maps to that quaternion, and \(\rho =\rho _s\oplus \tau \), so \[\rho (z)=-I_2\oplus I_3.\] Hence \(\rho (e_-)=(I-\rho (z))/2=P\), while \[\rho (e_+)=(I+\rho (z))/2=0\oplus I_3.\] The scalar \(0\) is the quaternion-module action of \(e_+\), not this operator.
Label the 4 imaginary vectors of Proposition [fdip-007G] by \[v_1=(1,1,1),\; v_2=(1,-1,-1),\; v_3=(-1,1,-1),\; v_4=(-1,-1,1).\] Their differences \[v_2-v_1=(0,-2,-2),\; v_3-v_1=(-2,0,-2),\; v_4-v_1=(-2,-2,0)\] are linearly independent: after removing the common factor \(-2\), the determinant of \[\begin {pmatrix}0&1&1\\1&0&1\\1&1&0\end {pmatrix}\] equals \(2\). A rotation fixing all 4 vertices therefore fixes a basis of \(\mathbb R^3\) and is the identity. The vertex action gives an injective homomorphism \(R_T\to S_4\).
Conjugation by \(i\) is the coordinate map \((x,y,z)\mapsto (x,-y,-z)\). Indeed, for \(v=xi+yj+zk\), \[iv=(-x)+(yk-zj),\qquad (iv)(-i)=xi-yj-zk,\] where the last step uses \(ji=-k\) and \(ki=j\). The same expansion with cycled units gives \[j:(x,y,z)\mapsto (-x,y,-z),\qquad k:(x,y,z)\mapsto (-x,-y,z).\] On the 4 vertices these are the permutations \[(1\;2)(3\;4),\qquad (1\;3)(2\;4),\qquad (1\;4)(2\;3).\] Each is even. Let \(u=-1+i+j+k\) and \(\omega =u/2\in 2T\). Direct multiplication yields \[\begin {array}{c|c} v&uv\overline u/4\\\hline v_1&v_1\\ v_2&v_4\\ v_3&v_2\\ v_4&v_3 \end {array}\] so \(\pi (\omega )\) fixes \(v_1\) and acts by the cycle \((2\;4\;3)\). This cycle is even. Conjugation by it permutes the three double transpositions: \[\begin {aligned} (2\;4\;3)(1\;2)(3\;4)(2\;4\;3)^{-1}&=(1\;4)(2\;3),\\ (2\;4\;3)(1\;4)(2\;3)(2\;4\;3)^{-1}&=(1\;3)(2\;4),\\ (2\;4\;3)(1\;3)(2\;4)(2\;4\;3)^{-1}&=(1\;2)(3\;4). \end {aligned}\] The cycle has order \(3\), while every non-identity element of that Klein subgroup has order \(2\), so the two subgroups meet only at the identity. These 12 permutations are the vertex permutations of products in \(R_T\). They are distinct, and \(|R_T|=12\), so they exhaust the vertex image. All 12 are even. Combined with injectivity, the vertex map is an isomorphism \(R_T\cong A_4\). The composite \(2T\to R_T\to A_4\) has kernel \(\{1,-1\}\).
For the \(d=3\) matrices of Definition [fdip-000R], \(\gamma _a^2=I\) and \(\gamma _a\gamma _b=-\gamma _b\gamma _a\) whenever \(a\ne b\). Set \[I\mapsto 1,\quad \gamma _1\gamma _2\mapsto i,\quad \gamma _2\gamma _3\mapsto j,\quad \gamma _1\gamma _3\mapsto k.\] Then \[(\gamma _1\gamma _2)^2=-\gamma _1^2\gamma _2^2=-I,\] and the same sign occurs for the other two products. Also \[(\gamma _1\gamma _2)(\gamma _2\gamma _3)=\gamma _1\gamma _3,\] and the two cyclic products match \(jk=i\) and \(ki=j\). These are the quaternion relations. They identify an action of the same abstract group on the even products. They do not state an intertwiner between left multiplication and the spatial operator \(\sum _j\gamma _j\nabla _j\).
Proposition. Status of the five criteria [fdip-00A1]AGENTDRAFTED
- November 2, 2026
Proposition. Status of the five criteria [fdip-00A1]AGENTDRAFTED
- November 2, 2026
For the binary tetrahedral datum of the finite spinor identities, the 5 criteria of the compatibility datum have the following status. Exactness, the selector effect and reference recovery are proved. The declared maps and the spinor separation are conditional. The unresolved part of the declared maps is the absence of the larger classical correspondences. That absence is not a nonexistence theorem.
The worked test in the background plan was left multiplication of \(2T\) on the spinor module \(\mathbb H\) of \(Cl^+(3)\). The test published in Proposition [fdip-00A0] is \(\rho _s\oplus \tau \) on \(\mathbb C^2\oplus \mathbb R^3\). Left multiplication on \(\mathbb H\cong \mathbb R^4\) is the realification of \(\rho _s\). The rotation summand \(\tau \) is additional.
Proof.
- November 2, 2026
Proof.
- November 2, 2026
Exactness is proved. The group is the Hurwitz model of \(2T\), and the coefficient field is \(\mathbb R\). The spinor fiber \(\mathbb C^2\) is realified as \(\mathbb R^4\), and the rotation fiber is \(\mathbb R^3\), so \(T(g)=\rho _s^{\mathbb R}(g)\oplus \tau (g)\) lies in \(GL_7(\mathbb R)\). Realification carries \(\rho _s(-1)=-I_2\) to \(-I_4\), and \(\tau (-1)=I_3\), so \(T(-1)=-I_4\oplus I_3\). The complex block form \(P=I_2\oplus 0\) in Proposition [fdip-00A0] realifies to \(I_4\oplus 0\). The graph action is the trivial action declared with these representations.
The declared maps are conditional. The two maps that are constructed are \(\pi :SU(2)\to SO(3)\) with kernel \(\{1,-1\}\), and \(2T\to A_4\) with the same kernel. Both are the finite identities of Proposition [fdip-00A0]. No homomorphism, kernel, cover or branching rule is constructed here for \(Sp(3,1)\), \(SU(3,1)\), \(SU(3,2)\), \(SL(4,\mathbb R)\), or a Hessian extension. Those comparisons remain open. Their absence is not a nonexistence theorem.
Separation is conditional. The spinor representation sends the quaternion \(-1\) to \(-I_2\), while the rotation representation sends it to \(I_3\). The representation datum already separates an internal factor \(1\otimes \rho \) from an action on the spinor factor, and the covariant Dirac operator requires Clifford compatibility before a binary rotation group can act as a gauge transformation. The quaternion multiplication table of Proposition [fdip-00A0] does not provide that compatibility law. The gravitational comparison available here is only the quotient \(SU(2)\to SO(3)\). A larger gravitational identification is unresolved.
The selector effect is proved for the operator named in the datum. With \(P=I_4\oplus 0\) the realified selector, \[PT(g)P=\rho _s^{\mathbb R}(g)\oplus 0.\] This is the block identity for that projection: it retains the realified spinor block and removes the rotation block. The same idempotent is not a link variable of the covariant Dirac operator, so this identity makes no claim about the kernel of that operator.
Reference recovery is proved for the declared comparison \(C\). That comparison is \(\tau :2T\to A_4\subset SO(3)\), the tetrahedral rotation representation. The kernel is \(\{1,-1\}\) and the image has order \(12\), as proved in Proposition [fdip-00A0]. The spinor fiber does not factor through that quotient. That caveat is stated under separation, above. It does not leave the recovery of this rotation representation unproved. The datum claims no lattice measure, continuum quantum field, or laboratory observable beyond this finite rotation representation.
The larger proposals as open tests [fdip-00A2]AGENTDRAFTED
- November 2, 2026
The larger proposals as open tests [fdip-00A2]AGENTDRAFTED
- November 2, 2026
The compatibility test fixes one finite spinor datum. The same 5 criteria now record the larger proposals left open by the status of that datum. Each proposal states the claim under test, the algebraic datum already in hand, the map that is missing, and whether any finite witness is available. An open mark records that absence. It is not a theorem that no later construction exists, and it is not a physical identification.
The 4 Lie-group names are those already listed as unconstructed in Proposition [fdip-00A1]. Their source claims are not the same. Three names do not occur in the cited Wilson paper. \(SL(4,\mathbb R)\) does, in a later section, and the Hessian route is the claim of Section 2.2. Both remarks below quote the claim that was rechecked and say what is missing. A correspondence still has to specify an action and a representation, an algebra map, any preserved structure or form, a unit-group choice where applicable, and the intended physical meaning, as required by why begin with 2T?. Resemblance is not a model, and neither remark below adopts a group.
The two remarks below keep these proposals open. Neither remark adopts a group as the symmetry of the lattice theory, and neither draws a no-go conclusion from the missing map.
Remark. Four Lie-group proposals remain open [fdip-00A3]AGENTDRAFTED
- November 2, 2026
Remark. Four Lie-group proposals remain open [fdip-00A3]AGENTDRAFTED
- November 2, 2026
The 4 names remain open tests against the compatibility datum. The claims below were checked in arXiv:2401.13000v4, the version reached by [wilson2024discrete]. The finite maps proved for the binary tetrahedral spinor are not claimed to factor through any of the 4 names.
\(Sp(3,1)\), \(SU(3,1)\) and \(SU(3,2)\) do not occur in that version. The FDIP record lists them as candidate groups mentioned while the programme was being planned. The known algebraic datum in these notes is the name alone: no dimension, real form, matrix realization, coefficient field, or action on a finite graph is fixed here. The missing map is a stated homomorphism, kernel, cover or branching rule, together with a selector and a reference object. No finite witness is supplied. All 5 criteria are open.
\(SL(4,\mathbb R)\) is named by Wilson. In Section 6.8, page 23, three rows of products of generators drawn from two copies of \(Q_8\) extend \(SO(4)\) to \(SL(4,\mathbb R)\) [wilson2024discrete, v4, Section 6.8, p. 23]. He gives two interpretations of that group: as a double cover of \(SO(3,3)\), and so as a symmetry of a six-dimensional spacetime, or as three directions of momentum and three of angular momentum inside a four-dimensional spacetime. He writes that this breaks the identification of \(SL(2,\mathbb C)\) with \(SO(3,1)\), so that the two become disjoint subgroups of \(SL(4,\mathbb R)\), and that the gain would be a generally covariant reading of the Standard Model. Section 7.3, page 25, later says that 4 quaternionic coordinates are acted on by \(SL(4,\mathbb R)\) as spacetime symmetries. The known datum here is that pair of sentences. No matrix realization on a finite graph, selector, or reference comparison is constructed in these notes. All 5 criteria are open. The open mark does not assert that a later realization is impossible.
Remark. The Hessian route remains an open test [fdip-00A4]AGENTDRAFTED
- November 2, 2026
Remark. The Hessian route remains an open test [fdip-00A4]AGENTDRAFTED
- November 2, 2026
The Hessian proposal is the route recorded in the Hessian-group outlook. That remark begins with \[Q_8\rtimes C_3\cong 2T\] and then names the iterated semidirect product \((G_{27}\rtimes Q_8)\rtimes C_3\). The actions in those products are part of the data. The name of the product does not choose them. The same remark states that a central scalar subgroup \(C_3\leq G_{27}\) has quotient the Hessian group of order 216, and that the larger group is a triple cover of that quotient. This chapter does not reconstruct \(G_{27}\), the semidirect actions, or that quotient.
The source sentence was rechecked in arXiv:2401.13000v4. Section 2.2 is page 5 of that file [wilson2024discrete, v4, Section 2.2, p. 5]. The locator pages 4 to 5 in Remark [fgap-001X] do not match this version. On page 5 Wilson states that the matrices for \(G_{27}\) and \(Q_8\) generate a group of order 216, the semidirect product \(G_{27}\rtimes Q_8\), and that the full group has order 648 and is the triple cover of the Hessian group. He writes that it can be interpreted as a finite analogue of \(U(1)\times SU(2)\times SU(3)\), and that the finite group is the iterated semidirect product \(G_{27}\rtimes Q_8\rtimes Z_3\). The cyclic factor of order 3 is the group written \(C_3\) in the display above. These notes record the interpretation and do not adopt it.
The known algebraic datum is the binary tetrahedral group already used in the finite spinor identities. The displays \(Q_8\rtimes C_3\cong 2T\) and \((G_{27}\rtimes Q_8)\rtimes C_3\) are not presentations and are not further data: their actions are not chosen, and neither \(G_{27}\) nor the order-216 quotient is constructed here. The missing map is a typed homomorphism from the iterated product, or from its order-216 quotient, into \(U(1)\times SU(2)\times SU(3)\) or into a group already constructed in these notes. The comparison with \(U(1)\times SU(2)\times SU(3)\) stays an attributed proposal in Remark [fgap-001X]. It is not an isomorphism, and the comparison motivation recorded beside that outlook is not a construction of the finite group.
The finite witness available now is \(2T\) alone. It does not determine \(G_{27}\) or the order-216 quotient. A witness that would meet the compatibility datum would specify one of those groups by a concrete model, a coefficient field, a representation on a named fiber, an action on a named finite graph, a selector, and one reference comparison. None of those slots is filled, and a matrix model would not by itself fill the missing action. Every criterion is open. That absence is not a no-go theorem and not a physical identification.
Discrete induction and its open interfaces [fdip-003W]AGENTDRAFTED
- November 3, 2026
Discrete induction and its open interfaces [fdip-003W]AGENTDRAFTED
- November 3, 2026
How can algebra and geometry organize induction and background variation? Gaussian elimination gives a finite example; the synthesis conjecture and finite interfaces distinguish this result from the further maps required.
The route through these explorations is the diagram opening the compatibility test. That test fixes one finite spinor datum. The larger proposals remain open tests. The conjecture and finite interfaces below remain distinct from those open questions.
The constructions now on this route include finite-group symmetry, selected backgrounds and connections, finite and compact gauge fields, reflection positivity, explicit transfer operators, Gauss's law, Grassmann integration, fermionic elimination, the covariant Dirac operator and the free Wilson remedy. The arrow from gauge fields to Euclidean time, drawn in the reader guide, is a reading prerequisite for the gauge transfer and for Gauss's law. Reflection positivity alone does not supply that time shift. The arrow from gauge fields to lattice fermions is a reading prerequisite for the covariant Dirac operator and for the free Wilson remedy that follows it, not for Grassmann integration or fermionic elimination, and not an identification of those operators with a physical electron.
The comparisons that remain open are these. The physical environment map \(E\) is not constructed. The supplied-circle limit controls one fixed Fourier mode; it is not a continuum limit of the full induced law, and no moduli map controls that limit. The enriched background groupoid and the geometric realization do not supply a site, a stack, or a descent that organizes those families. The larger proposals remain open tests. What the structure fixes and what it leaves free records that comparison. The chapters transcluded by Structure develop the questions of that part. None of these absences is a no-go theorem or a physical identification.
Wilson's claims. The tested claims are the two finite maps of Proposition [fdip-00A0]: conjugation \(SU(2)\to SO(3)\) and the quotient \(2T\to A_4\), both with kernel \(\{1,-1\}\). The larger proposals in § [fdip-00A2] stay open. Three of the 4 Lie names do not occur in the cited Wilson paper, and the Hessian and \(SL(4,\mathbb R)\) claims are recorded there as interpretations. The absence of a construction is not a no-go theorem and not a physical identification.
Next questions. What remains can be stated as 4 questions. The physical environment map \(E\) is still unconstructed. The continuum comparison is still the one fixed Fourier mode of Proposition [fdip-004J]. The higher-dimensional area law, fermion reflection positivity and fermion transfer, and infinite-volume reconstruction were not proved. Whether continuous space comes back at large scales, without being supplied, is left to a separate plan; § [fdip-009G] asks it and does not answer it. The enriched background groupoid and the geometric realization still do not supply a site, a stack, or a descent. Whether the context square organises the selectors remains open, and no stack is proved. Wilson's finite maps are tested, and the larger proposals remain open tests.
The conjecture and its finite evidence [fdip-009H]AGENTDRAFTED
- November 1, 2026
The conjecture and its finite evidence [fdip-009H]AGENTDRAFTED
- November 1, 2026
The synthesis conjecture proposes a wider theory. The finite evidence separates the constructions already established from their open interfaces.
Conjecture. A discrete induced arithmetic theory [fdip-003X]AGENTDRAFTED
- October 30, 2026
Conjecture. A discrete induced arithmetic theory [fdip-003X]AGENTDRAFTED
- October 30, 2026
The discrete induced theory is an arithmetic scheme equipped with a Clifford sheaf and a finite group action; the continuum limit and the background dependence are controlled by a map from a moduli stack; the numerical parameters of the resulting QFT are special values of L-functions attached to the arithmetic data.
This is a schematic research conjecture. An arithmetic family of forms, its Clifford algebra sheaf and a specified finite-group action are available finite constructions. The moduli-stack clause is an informal target for organizing families, isomorphisms and descent; no site, stack or continuum comparison map has been specified here. Nor has an arithmetic L-function or its special value been identified with a parameter of a quantum field theory (QFT). These terms describe the conjectured interfaces, not additional structures carried by every finite Gaussian model.
The first background-selection question is algebraic. Schematically, let \(B_{\mathrm {alg}}\) denote a chosen set of algebraic background data and \(\mathcal S\) a chosen set of admissible structures; a selector would be a map \[\sigma :B_{\mathrm {alg}}\longrightarrow \mathcal S.\] A physical interpretation would additionally require a set \(\operatorname {Env}_{\mathrm {phys}}\) of physical environments and a map \[E:\operatorname {Env}_{\mathrm {phys}}\longrightarrow B_{\mathrm {alg}}.\] Neither map is asserted to have been constructed by the enriched-background example. The finite interfaces and their limits specify what the present calculations do establish.
Remark. Finite evidence for the synthesis conjecture [fdip-003Y]AGENTDRAFTED
- November 2, 2026
Remark. Finite evidence for the synthesis conjecture [fdip-003Y]AGENTDRAFTED
- November 2, 2026
The synthesis conjecture connects discrete induction to arithmetic, symmetry, backgrounds, continuum limits and physical observables. The opposite-vertex elimination supplies a concrete finite comparison: averaging the removed fields preserves retained expectations, while fixing those fields can change them. The following 8 comparisons distinguish such proved constructions from the additional identifications required by each part of the conjecture.
- Arithmetic scheme. The arithmetic four-cycle family gives an explicit coefficient ring and separate open domains for a nondegenerate form, an invertible eliminated block and a trace observable. The bad fibers show why these domains differ. This constructs a family; it does not select a unique arithmetic model for a physical system. The background arc adds no arithmetic scheme.
- Clifford sheaf. The configuration Clifford algebra and its form-preserving maps extend to a sheaf compatible with scalar extension. For the enriched rational objects, Schur elimination multiplies the Galois characters of the retained and eliminated even centers. Primitive Dirichlet representatives must be formed after this product; multiplying their zero extensions need not give the same function, and no L-function multiplication rule follows. A physical spin or matter interpretation and an analytic coupling to observables require further maps. Configuration Clifford algebras and spatial Clifford modules are distinct objects. Grassmann integration is a later algebraic calculus. It is not this sheaf.
- Finite-group action. The specified half-turn, group-algebra action and sector marginals make symmetry and Gaussian elimination compatible under their stated hypotheses. The cycle half-turn fixes the even Clifford center pointwise; the nontrivial algebra involution of that center is a different action. These supplied symmetries do not select a physical gauge group or its dynamics. The background arc adds the real isotypic projectors of finite-group symmetry of Gaussian fields and the finite gauge laws of the pure-gauge torus and the surface character formula. Those laws are finite-group constructions. They do not choose a physical gauge group either.
- Backgrounds and moduli. The enriched background groupoid specifies objects, arrows, reference pairings and retained projections. Scalar descent preserves chosen invariants, while quadratic isometry can forget essential background data. The two-vertex comparison makes a second forgetting explicit: the same unweighted interval and retained endpoint admit different Gaussian variances. A groupoid of this kind alone supplies neither descent over a site nor a physical environment-selection map. Selected backgrounds and connections, from § [fdip-0059] through § [fdip-006C], keep that limit: a connection there is a fixed background, and the joint matter law of Example [fdip-0078] does not supply a site or a stack.
- Continuum comparison. The finite spatial Dirac calculation and its zero modes and nearest-neighbor comparison identify finite spectra and an operator mismatch. The supplied-circle limit now proves convergence of one fixed Fourier mode, its massive inverse and its Gaussian second moment. This is not convergence of the full induced law or a map from moduli controlling a continuum limit. The background arc does not extend this comparison. Its finite transfer operator Theorem [fdip-007U], the reflection counterexample Example [fdip-007P], and the free Wilson kernel Theorem [fdip-009V] remain finite-volume statements.
- Parameters and L-values. The trace ratio is an independently defined finite observable; its cycle values distinguish backgrounds. Two rational fibers are isometric as quadratic forms but have different trace ratios. The fiber-constancy criterion therefore excludes recovering this ratio from the rational quadratic-isometry class, and hence from its Clifford algebra, center character or any fixed collection of character-only L-values. No physical parameter is identified; arithmetic data that also retain the reference pairing and mass remain outside this obstruction. The background arc adds no L-value.
- Discrete induction. The Gaussian elimination theorem, retained expectation and cycle calculation construct an effective precision, normalization factor and new couplings, with symmetry transport. A formal quartic interaction composes under elimination through second order in its coupling and transports a supplied symmetry. The three-coordinate example exhibits constant, quadratic, quartic and sextic terms and computes a normalized connected four-point function; stationary elimination separates tree contributions from fluctuation terms. These finite formal calculations do not reconstruct eliminated data or supply a nonperturbative theory. The background arc adds the rooted-forest expansion Theorem [fdip-005V], the interacting selected background, and fermionic elimination, each at the scope stated in those notes.
- Physical equations and observables. These finite operators and normalized laws form a mathematical foundation. A comparison with Standard Model, quantum-field or general-relativistic equations still requires specified dynamics and observables, including the relevant gauge, matter, time and gravitational structures. No such physical identification is established by the finite identities above. The binary-tetrahedral test Proposition [fdip-00A0] adds two finite homomorphisms and no laboratory observable. The Hermitian Wilson counterexample Example [fdip-009W] is a convention check, not an identification.
What the structure fixes and what it leaves free [fdip-009G]AGENTDRAFTED
- November 3, 2026
What the structure fixes and what it leaves free [fdip-009G]AGENTDRAFTED
- November 3, 2026
Which features follow from a chosen finite structure, and which remain additional inputs?
Part VII compared the discrete physics with a continuous space that was supplied. The supplied-circle limit controls one fixed Fourier mode. Part XIII has since built cochains and their Hodge theory, a distance read from a commutator, and exact coarse-graining of a hierarchical precision. Whether the physics of continuous space comes back at large scales without being supplied can now be asked. Its answer is left to a separate plan. This section does not answer it, and it draws no continuum limit.
Wilson's finite groups stay first. The tested claims are the two finite maps of Proposition [fdip-00A0]: conjugation \(SU(2)\to SO(3)\) and the quotient \(2T\to A_4\), both with kernel \(\{1,-1\}\). Those maps fix the named kernels. The larger proposals remain open tests. The absence of a construction is not a no-go theorem and not a physical identification.
Several programmes outside this forest have not been read: a spectral derivation of the Standard Model, causal sets, loop quantum gravity, and the string landscape. This note does not record what they fix or leave free.
The Euler product, for \(\operatorname {Re}s>1\), is the product over primes not dividing \(2\det Q\) of \(\,(1-\hat Z_p(Q)\,p^{-s})^{-1}\). It equals \(L(s,\chi _D)\) times the product, over primes dividing \(2\det Q\) but not \(D\), of \(\,(1-\chi _D(p)\,p^{-s})\). The Gaussian induced action takes the weight to be half the logarithm of a determinant. The cycle scaling sends \((\log \det Q_n)/2-n\log n\) to a limit on the cycle. These are not the same object. This note does not identify the Euler product with that logarithm or with that limit.
The operator-algebra notes replace a supplied conditional expectation by the composition law for nested expectations (Theorem [fdip-008U]), and they replace a supplied fixed-point algebra by the image of the average (Theorem [fdip-008X]). The crossing block sets the reflection rank (Theorem [fdip-008W]). None of these is a continuum reconstruction.
On every square torus the Betti numbers are \((1,2,1)\) (Theorem [fdip-008Z]), and the harmonic cochains realize them (Theorem [fdip-0090]). The ordered compositions of exterior multiplication and contraction span the endomorphisms of the exterior algebra (Theorem [fdip-0092]). The cup product obeys the graded Leibniz rule and is not graded-commutative on cochains (Theorem [fdip-0093]). The note does not claim that the resulting Clifford representation is injective.
The Connes distance is computed on the stated finite triples (Theorem [fdip-0095]). The edge-source triple makes the distance the graph distance when each vertex has at most one incoming edge, and on one grid it lies strictly between the Euclidean distance and the graph distance (Theorem [fdip-0096]). On a triangle-free graph the gauge-dependent part of the fourth power of the massless covariant Laplacian is 8 times the sum of \(\cos \varphi _c-1\) over the undirected 4-cycles (Theorem [fdip-00A7]). The comparison of that trace with the logarithm of a massive determinant remains speculative. Neither finite trace is identified with a continuum limit.
Nested residue classes diagonalize a hierarchical precision (Theorem [fdip-0099]). Block means of that precision keep a hierarchical second-moment matrix (Theorem [fdip-009A]). For geometric coefficients, relevance of the top coefficient holds only for \(0<\lambda <1\). A hierarchical Gaussian has site fourth moment \(3\sigma ^4\) (Theorem [fdip-009B]). No non-Gaussian hierarchical fixed point is proved. These matrix relations do not by themselves produce a Gaussian measure on functions on the \(p\)-adic integers.
Surface gluing of the finite-group state sum is convolution of class functions (Theorem [fdip-00A8]). That convolution is not identified with the spatial transfer operator. On a finite incidence presentation, invariant tensors count the gauge orbits (Theorem [fdip-00A9]). One square in \(M_4(\mathbb C)\) cuts out 6 contexts with no global point, while each context separately has a character (Theorem [fdip-009E]). Whether that obstruction organises the selectors remains open (§ [fdip-009D]). Subgroup action groupoids form a groupoid-valued presheaf on the opposite of the subgroup poset (Theorem [fdip-009F]). No stack is proved.
Notes on Rubik's abstract polytopes [frap-0001]
📄PDFAGENTDRAFTED
- October 9, 2026
- Utensil Song
Notes on Rubik's abstract polytopes [frap-0001]
📄PDFAGENTDRAFTED
- October 9, 2026
- Utensil Song
These are the accompanying mathematical notes for the experimental research project FRAP, Formalizing Rubik's Abstract Polytopes. The notes ask how the mathematics of abstract polytopes, incidence actions and group constraints can explain the concrete practice of solving Rubik puzzles. The longer motivation, history and scope are recorded in why these notes connect polytopes and puzzles.
The route is staged so each abstraction earns a concrete consequence. We begin with incidence and shape symmetry, apply local facet moves to a tetrahedron and a cube, then pass to layered cubes, orientations and reachability. The later notes return to human methods, computer search, replay and play. How the notes are organized is the working route through those chapters; the companion repository is still an early research project, so formalization and executable solver work remain part of the scope.
How the notes are organized [frap-000C]AGENTDRAFTED
How the notes are organized [frap-000C]AGENTDRAFTED
The developed mathematics follows one practical question: what data must a move carry so that we can later compose moves and test reachability? Incidence, symmetry and moves answers it in order. First, polytopes, flags and facet symmetry describe the shape and show their role in triangle and tetrahedron examples. Next, facet moves turn a local facet rotation into an action on incidence positions, with tetrahedron and cube calculations that make the construction concrete. Only then do positions, orientations and global constraints separate a piece's destination from transport in its local frame, while transfer and the effect of dimension connect that transport with a group homomorphism and compute the relevant local abelianizations.
The cube examples above connect the general mathematics with solving and play. The longer motivation and formalization scope live in why these notes connect polytopes and puzzles; the later accounts use those concrete states and moves as their starting point:
The transition between the abstract facet action and the fixed-frame cube coordinates is recorded in how the cube models connect. Read it before the all-\(N\) law if the distinction between incidence positions, cubie fibres and observations is new.
- General Rubik puzzles: the incidence actions, framed orientations and transfer developed below.
- The layered-cube family: piece types, layer turns and conventions as \(N\) varies.
- The layered-cube law: all-\(N\) state coordinates and a source-backed sufficiency sketch for reachability.
- The complete three-layer cube: explicit outer generators, impossible states, the standard count and a worked cleanup.
- Human methods and computer search: recognizable cases, algebraic effects, usability, move costs and optimality. The complete layer-first method supplies one full human construction, and computer solving and efficiency supplies exact small search, admissible bounds and subgroup reduction.
- From move sequences to play: notation, scrambling, recognition, replay and complete solves, including the worked replay and projected lower bound.
Further connections relate the developed orientation and transfer calculations to label transport and topology and scrambling and search functions. The quotient-compatible move account gives the criterion for an identification of observations to inherit a puzzle action. Together these results compare transport, randomization and information loss around the same concrete move.
Five encounters with a cube [frap-001C]AGENTDRAFTED
Five encounters with a cube [frap-001C]AGENTDRAFTED
Put a solved three-layer cube on a table and turn its right face once. The move is familiar, but it raises concrete puzzles: which labelled pieces moved, why can a visually plausible arrangement be impossible, and how can another person undo the turn without watching the first hand? Begin with these experiences, then introduce only the distinctions needed to explain them.
One turn is larger than the visible face
One turn is larger than the visible face
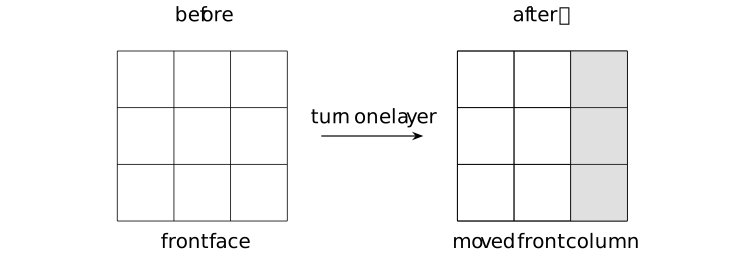
The shaded strip is only the visible part of the layer: the same stickers cross the front, right, back, top, and bottom faces; viewed from above, the top-face part is the corresponding rightmost strip. A whole-cube rotation would change the viewing frame, whereas this face move keeps the six centres fixed and changes one layer. The layered-cube family makes this distinction for every \(N\); the complete three-layer cube spells it out for the six outer generators.
A sticker needs a home and a frame
A sticker needs a home and a frame
Definition. Cubies, sticker states, and fixed local frames [frap-001D]AGENTDRAFTED
Definition. Cubies, sticker states, and fixed local frames [frap-001D]AGENTDRAFTED
A description with a fixed global viewing frame needs three pieces of vocabulary. A cubie is one physical unit of the layered cube, with a home position and the visible stickers incident to that position. For a three-layer cube these are the eight corners, twelve edges and six centres described in how the cube models connect. Bonzio, Loi and Peruzzi use this cubie decomposition in their general model [bonzio2018nxnxn, Sections 2-3]; the visible-sticker formulation in this fixed global viewing frame is our adaptation to the present cube convention.
For \(N=3\), let \(\mathcal S\) be the 54 labelled visible stickers and let \(\mathcal P=\{(p,n):p\in \{-1,0,1\}^3,\ \lVert p\rVert _\infty =1,\ n \text { is an incident outward normal at }p\}\). Thus \(\lvert \mathcal P\rvert =54\). A sticker state is a bijection \(s:\mathcal S\xrightarrow {\sim }\mathcal P\): every valid surface slot has exactly one occupant. The solved assignment \(s_0\) is the reference state, and \(s_0^{-1}\mathbin {\circ }s:\mathcal S\to \mathcal S\) records the state as a permutation of sticker labels, while \(s\mathbin {\circ }s_0^{-1}:\mathcal P\to \mathcal P\) records the same state as a permutation of the 54 slots. A move \(m:\mathcal P\to \mathcal P\) acts on the state by \(m\mathbin {\circ }s:\mathcal S\to \mathcal P\), so it left-composes the slot permutation by \(m\) and left-composes the sticker-label permutation by the transported move \(s_0^{-1}\mathbin {\circ }m\mathbin {\circ }s_0\). Marchetti's position-and-label transport gives the structural pattern [marchetti2025rubik, Section 3.1, Definition 7 and equation (5)]; the present 54-slot bijection is our adaptation of that pattern to the three-layer cube. The correspondence between these slots, cubie fibres, and the coordinates \((\sigma ,x;\tau ,z)\) is made explicit in how the cube models connect.
A fixed local frame specializes the local frame: it is a chosen reference ordering of the incident sticker directions at each cubie. A move records both the cubie's destination and how its labels are transported relative to that ordering. The six centre directions keep the global viewing frame fixed; a whole-cube rotation would change that frame and is a separate symmetry. These definitions distinguish the sticker state from a colour observation, which forgets labels that look alike.
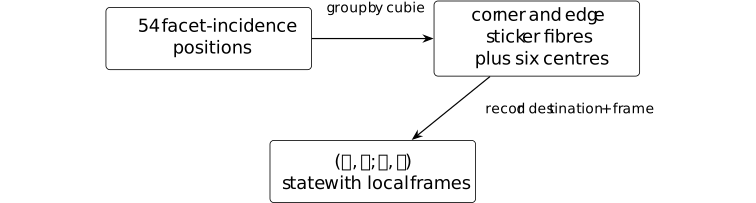
A complete cube description tracks each sticker's cubie and transported fixed local frame. How the cube models connect follows one sticker through incidence position, cubie fibre, and fixed-local-frame coordinate. A colour quotient forgets labels, while a larger cube adds positions, so the state space changes with the question.
A plausible state can still be impossible
A plausible state can still be impossible
Take a solved cube and twist one corner in place. The resulting sticker state still puts every sticker in a cubie-sized home, and the three colours at that corner look locally consistent. But the corner orientations now have sum \(1\) modulo \(3\), whereas every face turn preserves sum \(0\). No sequence of legal turns can produce this state.
The complete three-layer cube derives the matching edge and permutation restrictions from the six generators. The calculation is useful at the table: it tells a solver when a scrambled-looking object was assembled illegally, and it tells a proof which state space is worth searching.
A human algorithm has to preserve these legal states while it borrows pieces from completed areas.
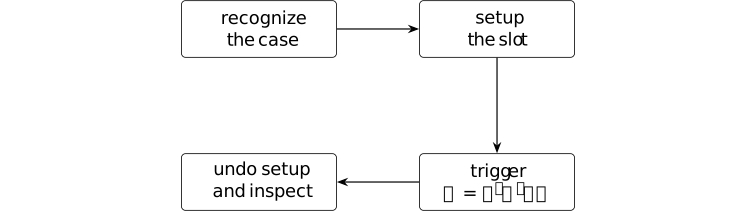
A formula often disturbs pieces that were already placed. The disturbance is acceptable only when the setup is undone and the completed pieces return. A working slot, a trigger, and an inverse setup make that promise visible. The complete layer-first method repeats this pattern through the cross, the first layer, the middle layer, and the last layer. Its completeness depends on the preservation and termination checks, not on the formula's familiarity.
Undoing a scramble checks the notation
Undoing a scramble checks the notation
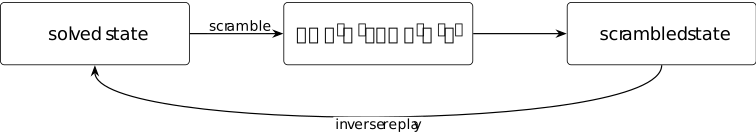
The worked replay and projected lower bound fixes the viewing convention, records the ten tokens, and applies their inverse. Sticker replay returns to solved. A corner-only projected search finds no solution of depth at most two, so the evidence is the bounded statement
\[3\le d_{\rm HTM}\le 10.\]The inverse word is an upper-bound witness; the projected search is a lower-bound witness. The computer account explains why these checks do not prove that ten is shortest. A state, a word, and a replay log are enough to test the notation before asking for a general solver.
Changing one ingredient changes the problem
Changing one ingredient changes the problem
Once the move, its frame, its local repair, and its replay are explicit, three variations separate the effects of enlarging the cube, changing the shape, and forgetting labels.
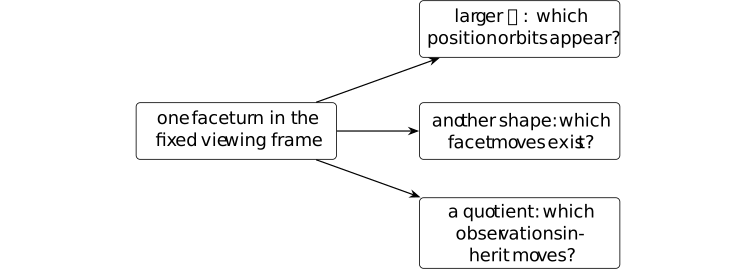
The layered-cube family develops the first variation; the incidence and facet construction in incidence, symmetry and moves develops the second; and which moves survive a quotient? gives the descent condition for the third. Framed orientations, label transport and topology, and scrambling, spectra and search then study the extra information each variation introduces or forgets. Their hypotheses stay attached to the concrete move that prompted the question.
A face turn can therefore be drawn, named, replayed, and checked before it is generalized. The resulting state maps and invariants support later formal certification or measured comparisons, while the examples here make clear which claim each later programme would have to establish.
From incidence to moves [frap-0002]AGENTDRAFTED
From incidence to moves [frap-0002]AGENTDRAFTED
To describe a puzzle move without committing to coordinates, we need an incidence record that says which pieces and labels belong together. Faces and incidence define an abstract polytope without choosing lengths or an embedding [schulte2017regular, Section 2]. Regularity supplies shape symmetries; the Rubik construction applies facet rotations locally to incidence positions [marchetti2025rubik, Definitions 5--6]. The sections below first make the shape visible in triangle and tetrahedron examples, then build this action and calculate its tetrahedron and cube consequences.
Faces, flags, and the symmetry of a shape [frap-0008]AGENTDRAFTED
Faces, flags, and the symmetry of a shape [frap-0008]AGENTDRAFTED
A local turn needs a shape-level answer to two questions: which faces are incident, and which symmetries preserve those incidences? An abstract polytope retains the incidence of vertices, edges and faces without prescribing distances or angles. Schulte's flag formulation [schulte2017regular, Section 2] leads from these incidences to symmetries and to the extension of a facet symmetry used in local puzzle moves.
Definition. Abstract polytopes and flags [schulte2017regular, Section 2] [frap-000D]AGENTDRAFTED
Definition. Abstract polytopes and flags [schulte2017regular, Section 2] [frap-000D]AGENTDRAFTED
An abstract \(n\)-polytope, for \(n\geq 0\), is a partially ordered set \(P\) of faces with a least face \(F_{-1}\) and greatest face \(F_n\). Every chain extends to a maximal chain, called a flag, with exactly \(n+2\) faces. Faces in each flag have ranks \(-1,0,\ldots ,n\), consistently across flags. Faces other than the least and greatest are proper; vertices, edges and facets have ranks \(0,1,n-1\).
The diamond condition requires exactly two faces of rank \(i\) between faces \(F<G\) of ranks \(i-1\) and \(i+1\), for \(0\leq i<n\). Two flags are adjacent if they differ in exactly one proper face. Strong flag connectivity requires any two flags to be joined by adjacent flags, each containing their intersection.
Thus, for each \(0\leq i<n\), each flag has a unique adjacent flag differing in rank \(i\). Strong flag connectivity restricts paths to these adjacent flags, each containing the endpoint flags' intersection; arbitrary paths through the least face would connect every pair without imposing an axiom. These conditions prescribe incidence without choosing lengths or angles.
A rank-zero polytope is a two-element chain. A rank-one polytope has two vertices between its least and greatest faces. These low-rank cases occur as sections of higher-rank polytopes.
Definition. Sections and vertex figures [schulte2017regular, Section 2] [frap-000E]AGENTDRAFTED
Definition. Sections and vertex figures [schulte2017regular, Section 2] [frap-000E]AGENTDRAFTED
Let \(P\) be a abstract polytope. For faces \(F\leq G\) of ranks \(i,j\), its section \(G/F\) is the interval \(\{H:F\leq H\leq G\}\), with ranks shifted so that \(F\) has rank \(-1\). For \(F<G\), it is an abstract polytope of rank \(j-i-1\geq 0\). For \(F=G\), the singleton section is called the rank-\(-1\) polytope. These low ranks allow all intervals, including vertex figures of polygons and intervals between consecutive faces.
The section \(F_n/v\) at a vertex \(v\) is its vertex figure. Its vertices are the edges through \(v\); its faces record the incidences above \(v\). A facet \(H\) is viewed as the section \(H/F_{-1}\).
Example. Flags of a triangle and a tetrahedron [frap-000F]AGENTDRAFTED
Example. Flags of a triangle and a tetrahedron [frap-000F]AGENTDRAFTED
The face-poset construction of [schulte2017regular, Section 2] gives the following elementary examples of flags. A triangle has the empty face, three vertices, three edges and the whole triangle, of ranks \(-1,0,1,2\). The flag \(\varnothing <1<12<123\) has rank-zero neighbor \(\varnothing <2<12<123\) and rank-one neighbor \(\varnothing <1<13<123\). There are \(3\cdot 2=6\) flags.
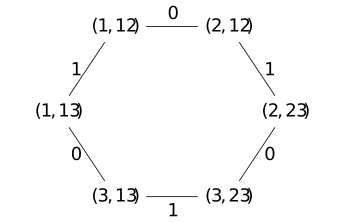
Each vertex in this flag graph records the vertex and edge of one flag; the common empty and greatest faces are suppressed. Edge labels give the rank changed by adjacency.
A tetrahedron has all subsets of \(\{1,2,3,4\}\) as faces, ordered by inclusion; a nonempty face with \(k\) vertices has rank \(k-1\). Its flag \(\varnothing <1<12<123<1234\) exhibits all five ranks. The vertex figure at \(1\) is a triangle: its vertices correspond to the three incident edges. A cube also has a triangular vertex figure, although its facets are squares. Local and global shapes carry different information.
The triangle and tetrahedron calculation now supplies a concrete check: the flag graph records which flags are adjacent; a vertex figure records the local neighborhood seen from one vertex. With those objects in hand, the next steps ask which incidence-preserving maps act on all flags and how a symmetry of one facet can be extended.
Definition. Automorphisms and regularity [schulte2017regular, Section 2] [frap-000G]AGENTDRAFTED
Definition. Automorphisms and regularity [schulte2017regular, Section 2] [frap-000G]AGENTDRAFTED
An automorphism of a abstract polytope \(P\) is a bijection \(a:P\to P\) satisfying \(F\leq G\iff a(F)\leq a(G)\). Automorphisms form a group \(\Gamma (P)\) under composition; in \(ab\), the map \(b\) acts first. They preserve ranks and act on flags face by face.
The polytope is regular if this action is transitive on flags. The tetrahedron is regular: a permutation of its four vertices sends any flag to any other.
The underlying order automorphism is represented by
OrderIso with equal source and target. This declaration does
not impose the polytope axioms or assert regularity.
Lemma. A flag determines an automorphism [schulte2017regular, Section 2, p. 4] [frap-000H]AGENTDRAFTED
Lemma. A flag determines an automorphism [schulte2017regular, Section 2, p. 4] [frap-000H]AGENTDRAFTED
An automorphism of an abstract polytope fixing every face of one flag is the identity. Consequently the automorphism group of a regular polytope acts freely and transitively on its flags.
The cited paragraph preceding Lemma 2.1 states simple transitivity for regular polytopes. The elementary argument below also proves freeness without assuming regularity.
Proof.
Proof.
For a flag adjacent to a pointwise fixed flag, only one rank has changed. The unchanged neighboring ranks bound a diamond condition with two possible faces. One is fixed, so the other is fixed too. The adjacent flag is therefore fixed pointwise. Propagating along the connected flag graph fixes every flag. Every face belongs to a flag, so every face is fixed. Transitivity is the definition of being regular.
Remark. Distinguished generators and the intersection property [frap-000I]AGENTDRAFTED
Remark. Distinguished generators and the intersection property [frap-000I]AGENTDRAFTED
Choose a base flag \(\Phi \) in a regular abstract polytope \(P\) of rank \(n\). By flag freeness, there is a unique automorphism \(\rho _i\) taking \(\Phi \) to its rank-\(i\) neighbor, for \(0\leq i<n\). The diamond condition and uniqueness give \(\rho _i^2=1\). For \(|i-j|>1\), the two rank changes are independent; \(\rho _i\rho _j\) and \(\rho _j\rho _i\) agree on \(\Phi \), hence are equal. Connectivity shows that the \(\rho _i\) reach every flag, so they generate \(\Gamma (P)\). These are the distinguished generators of [schulte2017regular, Section 5, pp. 13--14].
For \(I\subseteq \{0,\ldots ,n-1\}\), put \(G_I=\langle \rho _i:i\in I\rangle \). They also satisfy
\[G_I\cap G_J=G_{I\cap J}.\]This intersection property is part of the string C-group description [schulte2017regular, Section 5, equation (18)]. Involution and nonadjacent commutation relations alone do not reconstruct a polytope; the group-theoretic characterization includes this additional condition [schulte2017regular, Section 5, p. 14].
Lemma. Extending a symmetry of one facet [frap-000J]AGENTDRAFTED
Lemma. Extending a symmetry of one facet [frap-000J]AGENTDRAFTED
Let \(H\) be a facet of a regular abstract polytope \(P\) of rank \(n\geq 2\). Restriction gives an isomorphism
\[\operatorname {Stab}_{\Gamma (P)}(H)\cong \Gamma (H/F_{-1}).\]In particular the facet is regular, and each of its automorphisms has a unique extension fixing \(H\). This is a consequence of the flag action in [schulte2017regular, Section 2 and Lemma 2.1]; the argument follows.
Proof.
Proof.
Extend a flag of the facet section by the greatest face of \(P\). A stabilizer element restricting to the identity fixes this whole flag and is the identity by flag freeness. Restriction is therefore injective.
Given a facet automorphism \(\alpha \), the regular action supplies an automorphism of \(P\) taking the extended flag to the extension of its image under \(\alpha \). It fixes \(H\). Its restriction agrees with \(\alpha \) on the chosen facet flag, so flag freeness in the facet makes these restrictions equal. This proves surjectivity. The same use of same regular action with any two facet flags shows that the facet is regular.
Turning a facet into a puzzle move [frap-0009]AGENTDRAFTED
Turning a facet into a puzzle move [frap-0009]AGENTDRAFTED
Once the shape symmetries are known, the next question is local: how can a turn change only the positions incident to one chosen facet while carrying their labels along? A facet rotation extends to a symmetry of the whole shape, but a puzzle move applies it only at positions incident to the chosen facet. Marchetti's construction retains both entries of each incidence pair [marchetti2025rubik, Definitions 5--6]. We use finite regular abstract polytopes of rank at least three; the extension lemma itself does not require finiteness.
Definition. The rotation subgroup [marchetti2025rubik, Definition 4] [frap-000K]AGENTDRAFTED
Definition. The rotation subgroup [marchetti2025rubik, Definition 4] [frap-000K]AGENTDRAFTED
Let \(Q\) be a regular abstract polytope of rank \(m\geq 2\). Choose a base flag and its distinguished generators (involutions) \(\rho _0,\ldots ,\rho _{m-1}\). Its rotation subgroup is
\[\Gamma ^+(Q)=\langle \rho _{j-1}\rho _j:1\leq j<m\rangle .\]The index starts at \(1\): for a polygon, the single adjacent pair \(\rho _0\rho _1\) generates its rotations. For triangles and squares these are the usual cyclic rotation groups.
Equivalently, \(\Gamma ^+(Q)\) consists of the elements represented by even-length words in the distinguished involutions. Indeed every pair \(\rho _i\rho _j\) is a product of adjacent pairs or their inverses, by cancellation along the index interval. Conjugating an even word by a distinguished involution again gives an even word, so this subgroup is normal. A change of base flag conjugates the distinguished generators and therefore leaves the subgroup unchanged. We do not require it to have index two for every abstract polytope.
Definition. Incidence positions and facet moves [marchetti2025rubik, Definitions 5--6] [frap-000L]AGENTDRAFTED
Definition. Incidence positions and facet moves [marchetti2025rubik, Definitions 5--6] [frap-000L]AGENTDRAFTED
Let \(P\) be a finite regular abstract polytope of rank \(n\geq 3\), with least and greatest faces \(F_{-1},F_n\). Write \(P^\circ =P\setminus \{F_{-1},F_n\}\). The incidence positions are
\[\mathcal R(P)=\{(F,G)\in P^\circ \times P^\circ :F\leq G\}.\]Choose a facet \(H\) and an element \(\alpha \) of the rotation subgroup \(\Gamma ^+(H/F_{-1})\). The facet extension lemma gives its unique extension \(\widehat \alpha \in \Gamma (P)\) fixing \(H\). The corresponding facet move is
\[\mu _{H,\alpha }(F,G)= \begin {cases} (\widehat \alpha (F),\widehat \alpha (G)),&F\leq H,\\ (F,G),&F\not \leq H. \end {cases}\]The first entry decides where the shape automorphism is applied; the second entry is transported with it. The facet is part of the move's name: one shape automorphism may stabilize several facets and give different local moves. Each move is a permutation of \(\mathcal R(P)\).
Lemma. The inverse of a facet move [frap-000M]AGENTDRAFTED
Lemma. The inverse of a facet move [frap-000M]AGENTDRAFTED
Let \(P\) be a finite regular abstract polytope of rank \(n\geq 3\), \(H\) a facet and \(\alpha \in \Gamma ^+(H/F_{-1})\) a facet rotation. The facet move \(\mu _{H,\alpha }\) is a permutation of \(\mathcal R(P)\), with
\[\mu _{H,\alpha }^{-1}=\mu _{H,\alpha ^{-1}}.\]This follows directly from the construction in [marchetti2025rubik, Definitions 5--6].
Proof.
Proof.
An automorphism preserves proper faces and the order relation, so the moving branch remains in \(\mathcal R(P)\). Since \(\widehat \alpha (H)=H\), the condition \(F\leq H\) holds exactly when \(\widehat \alpha (F)\leq H\). Thus the moving and fixed subsets are preserved separately. On the moving subset the extension of \(\alpha ^{-1}\) is \(\widehat \alpha ^{-1}\) by uniqueness, and cancels the first map. On the fixed subset both maps are the identity.
The general construction combining permutations of complementary
subsets is Equiv.Perm.subtypeCongr; its inverse formula is
Equiv.Perm.subtypeCongr.symm. Here the predicate is \(F\leq H\),
the moving permutation is the restricted shape automorphism and the other
permutation is the identity. These declarations supply that general
combination; the polytope-specific preservation argument is the proof above.
The inverse lemma makes the local action reversible. The tetrahedron calculation that follows is a small witness for why the facet is part of a move's identity: two locally valid turns can act differently on the same incidence record and need not commute.
Example. Two turns of a tetrahedron [frap-000O]AGENTDRAFTED
Example. Two turns of a tetrahedron [frap-000O]AGENTDRAFTED
Represent the faces of a tetrahedron by subsets of \(\{1,2,3,4\}\). We calculate facet moves from [marchetti2025rubik, Definitions 5--6]. For the facet \(H=123\), take an element of the rotation subgroup with global extension \(\widehat \alpha =(123)\), fixing \(4\). The vertex-edge records follow the cycle
\[(1,12)\longmapsto (2,23)\longmapsto (3,13)\longmapsto (1,12).\]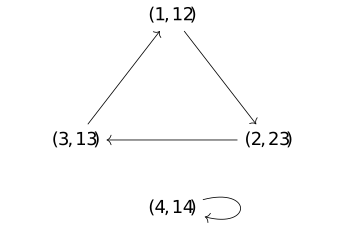
Every arrow is the local move \(\mu _{H,\alpha }\). The record \((4,14)\) stays fixed because \(4\not \leq H\), although the global shape symmetry sends it to \((4,24)\). The diagram records this permutation of incidence positions, rather than the tetrahedron's face graph.
For records whose second entry is a facet, the same move gives
\[(1,124)\longmapsto (2,234),\qquad (12,124)\longmapsto (23,234),\qquad (4,124)\longmapsto (4,124).\]The last record is fixed even though the global symmetry changes its second entry. Now let \(K=124\) and take an element of the rotation subgroup with global extension \(\widehat \beta =(124)\). Applying the \(H\)-move and then the \(K\)-move sends
\[(1,124)\xrightarrow {\mu _{H,\alpha }}(2,234) \xrightarrow {\mu _{K,\beta }}(4,134).\]Reversing their order gives \((1,124)\mapsto (2,124)\mapsto (3,234)\), so the two moves do not commute. Each has order three: its cube is the identity on both branches, and its displayed action is nontrivial.
The tetrahedron witness motivates the generated move group: reachable labelled configurations are products of these reversible local turns. The ordinary cube calculation then shows how the same definition compares with visible stickers and which data it leaves out.
Definition. The Rubik group and labelled configurations [frap-000N]AGENTDRAFTED
Definition. The Rubik group and labelled configurations [frap-000N]AGENTDRAFTED
For a finite regular abstract polytope \(P\) of rank \(n\geq 3\), the Rubik group is the subgroup generated by all facet moves:
\[\operatorname {Rub}(P)= \langle \mu _{H,\alpha }:H\text { a facet},\quad \alpha \in \Gamma ^+(H/F_{-1})\rangle \leq \operatorname {Sym}(\mathcal R(P)).\]This is Marchetti's generated group of permutations [marchetti2025rubik, Section 3, p. 6, following Definition 6]. The inverse lemma ensures that the generators are permutations.
Give each incidence position its own initial label. A labelled configuration can be represented by the permutation carrying each initial label to its current position. The identity is the solved configuration; the reachable labelled configurations are the elements of \(\operatorname {Rub}(P)\). A new move acts on the left: applying \(\mu \) to configuration \(g\) gives \(\mu g\), with \(g\) acting first. A visible coloring may identify several labelled configurations, so a solved visible coloring need not determine the labelled permutation.
Example. One ordinary cube face turn [frap-000P]AGENTDRAFTED
Example. One ordinary cube face turn [frap-000P]AGENTDRAFTED
Realize the cube as \([-1,1]^3\) and let \(H\) be the facet \(z=1\). The facet move construction of [marchetti2025rubik, Definitions 5--6] gives the following explicit outer-face action. The shape rotation
\[q(x,y,z)=(y,-x,z)\]is a clockwise quarter-turn when viewed from positive \(z\), with \(x\) rightward and \(y\) upward. Its restriction to \(H\) supplies our move. The corner \((1,1,1)\) goes to \((1,-1,1)\), and its color on \(y=1\) goes to the color position on \(x=1\). The corresponding corner at \(z=-1\) is fixed by the puzzle move, although the global map \(q\) moves it.
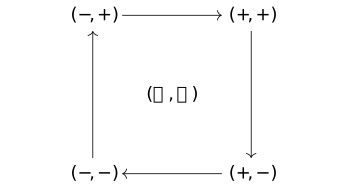
The signs give the \(x,y\) coordinates of the four corners on \(z=1\). The arrows show their clockwise motion; the central incidence record \((H,H)\) stays fixed. No orientation of a marked center is recorded.
Restricting the second entry to facets gives \(8\cdot 3+12\cdot 2+6=54\) incidence positions: three per corner, two per edge and one per face center. The turn moves twelve corner stickers and eight edge stickers, fixing the other thirty-four positions, including the unmarked center of the turned face. This is the usual outer-face action on visible stickers of a \(3\times 3\times 3\) cube in a fixed frame.
The full incidence set has \(8\cdot 7+12\cdot 3+6=98\) elements: above each vertex are that vertex, three edges and three facets; above each edge are itself and two facets. The facet-colored subset is invariant under every move. Its restricted action supplies the comparison with ordinary stickers; a faithful restriction for all abstract polytopes is not needed. Marked center orientations and inner-layer turns are additional data, absent from this comparison.
The local action determines which positions participate and how their incident labels travel. Frames and orientation separate this transport into a destination and a local orientation.
Positions, orientations, and global constraints [frap-000A]AGENTDRAFTED
Positions, orientations, and global constraints [frap-000A]AGENTDRAFTED
After a facet move, a piece can reach the right position with the wrong local orientation. The first question is therefore what data records both the destination and the frame carried by the piece. Local frames turn this transport into group coordinates, as in [marchetti2025rubik, Section 3.1]. We then derive the composition law, a frame-independent total-orientation character, and the additional test that makes this character a conserved quantity for cube face turns.
Definition. Framed transports [frap-000Q]AGENTDRAFTED
Definition. Framed transports [frap-000Q]AGENTDRAFTED
Let \(I\) be a finite set of positions, \(\Omega \) a nonempty set, and \(K\) a group acting faithfully on \(\Omega \). At each position \(i\), choose a set \(X_i\) of local labels and a bijective local frame \(c_i:\Omega \to X_i\). Keep the fibers distinct by using the tagged union
\[E=\coprod _{i\in I}X_i=\{(i,y):i\in I,\ y\in X_i\}.\]A framed transport is a permutation of \(E\) given by a position permutation \(\pi \in \operatorname {Sym}(I)\) and elements \(a_i\in K\), with
\[g(i,c_i(x))=(\pi (i),c_{\pi (i)}(a_i x)).\]Write \(g=(\pi ,a)\). Its local factors are indexed by the source position. Nonempty fibers determine \(\pi \) uniquely, and faithfulness determines each \(a_i\) uniquely. Conversely every such pair gives a permutation: in framed coordinates its inverse sends \((j,x)\) to \((\pi ^{-1}(j),a_{\pi ^{-1}(j)}^{-1}x)\).
This finite-position model isolates the coordinate mechanism of [marchetti2025rubik, Section 3.1, Definition 7 and equation (5)]. Which local label sets and local group describe a particular puzzle must still be justified for that puzzle. The requirement that a transport moves whole fibers is part of the model.
Under composition these transports form a wreath product
\(K\wr \operatorname {Sym}(I)\). The normal subgroup \(K^I\) acts within
fibers, and position permutations reorder its factors. In
TauCeti.WreathProduct, a pair is stored using the
destination-indexed function \(A_j=a_{\pi ^{-1}(j)}\). Its permutation
action is TauCeti.WreathProduct.imprimitiveToPerm_apply;
the nonempty-fiber and faithful-action hypotheses give its injectivity in
TauCeti.WreathProduct.imprimitiveToPerm_injective.
The bijections \(c_i\) identify that action on \(I\times \Omega \) with
the action on \(E\) above.
Lemma. Composition of framed transports [frap-000R]
L∃∀NAGENTDRAFTED
Lemma. Composition of framed transports [frap-000R]
L∃∀NAGENTDRAFTED
Let \(I\) be finite and let \(K\) act faithfully on a nonempty \(\Omega \), with bijective frames \(c_i:\Omega \to X_i\). Write two framed transports as \(g=(\pi ,a)\) and \(h=(\sigma ,b)\), acting in coordinates by \(g(i,x)=(\pi (i),a_i x)\) and \(h(i,x)=(\sigma (i),b_i x)\). With left actions, applying \(g\) and then \(h\) gives the composition law
\[hg=(\sigma \pi ,(b_{\pi (i)}a_i)_{i\in I}).\]
Proof.
Proof.
The intermediate coordinates are \((\pi (i),a_i x)\). Applying \(h\) evaluates its local map at that intermediate position, giving \((\sigma \pi (i),b_{\pi (i)}a_i x)\). Thus a local factor must be multiplied at its transported position index.
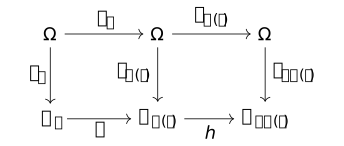
The vertical arrows are the chosen frames; the bottom arrows are the restrictions of the actual transports. Each square commutes. Along the top row, the second factor is evaluated at \(\pi (i)\), explaining the shifted index in the composite. This expands the wreath-product coordinates of [marchetti2025rubik, Section 3.1, pp. 6--7]. The wreath product uses destination-indexed factors in the linked formalization.
The linked multiplication theorem uses destination-indexed factors. Set \(A_j=a_{\pi ^{-1}(j)}\) and \(B_j=b_{\sigma ^{-1}(j)}\). Its factor for \(hg\) at destination \(j\) is
\[B_j A_{\sigma ^{-1}(j)} =b_{\sigma ^{-1}(j)}a_{\pi ^{-1}\sigma ^{-1}(j)}.\]Putting \(i=(\sigma \pi )^{-1}(j)\) makes this exactly \(b_{\pi (i)}a_i\). Thus the theorem and the displayed source-indexed law use the same multiplication order.
Theorem. The abelianized total orientation [frap-000S]AGENTDRAFTED
Theorem. The abelianized total orientation [frap-000S]AGENTDRAFTED
Let \(I\) be finite, let \(K\) act faithfully on a nonempty \(\Omega \), and choose bijective frames \(c_i:\Omega \to X_i\). For a framed transport \(g=(\pi ,a)\), let \(K_{\mathrm {ab}}=K/[K,K]\) be its abelianization, where \([K,K]\) is generated by \(uvu^{-1}v^{-1}\), and write \([a]\) for the class of \(a\). The total-orientation character
\[\chi (g)=\prod _{i\in I}[a_i]\quad \hbox {in }K_{\mathrm {ab}}\]is a homomorphism, independent of replacing the frames by \(c_i'=c_i t_i\) for \(t_i\in K\). This is the canonical character in [marchetti2025rubik, Section 3.1, p. 7]; the proof below gives both assertions directly in source-indexed coordinates.
Proof.
Proof.
For \(h=(\sigma ,b)\), the composition law and commutativity of the target give
\[\chi (hg)=\prod _i[b_{\pi (i)}][a_i] =\left (\prod _j[b_j]\right )\left (\prod _i[a_i]\right ) =\chi (h)\chi (g).\]The middle equality reindexes using the bijection \(\pi \). In the new frames the local map is \(a_i'=t_{\pi (i)}^{-1}a_i t_i\). Its abelianized product contains each \([t_i]\) and its inverse exactly once, so these cancel and leave \(\chi (g)\).
Frame independence here concerns changes within the chosen group of
frames. Reversing a common orientation convention can also change the
identification of the target group. The target and its quotient map are
Abelianization and Abelianization.of; the total
product and its frame independence are the argument above.
Remark. When a character is conserved [frap-000T]AGENTDRAFTED
Remark. When a character is conserved [frap-000T]AGENTDRAFTED
For finite \(I\), the ambient coordinate group \(W=K\wr \operatorname {Sym}(I)\) has the total-orientation character \(\chi (\pi ,a)=\prod _i[a_i]\in K_{\mathrm {ab}}\). If a puzzle's allowed moves form a set \(S\subseteq W\), its legal group is \(G=\langle S\rangle \), usually a proper subgroup of \(W\). Then
\[G\subseteq \ker \chi \quad \Longleftrightarrow \quad \chi (s)=1\quad \hbox {for every }s\in S.\]The forward implication includes each generator. Conversely the kernel of a homomorphism is a subgroup, so it contains all products and inverses of generators lying in it. This is the generator-check step discussed after the canonical character in [marchetti2025rubik, Section 3.1, p. 7]. Its premise must be verified for the chosen moves.
The nonabelian product of local factors need not be independent of order or frames. Abelianization makes reindexing and frame cancellation valid, but neither of those operations says that \(\chi (s)=1\). The cycle criterion supplies a sufficient test, applied explicitly to cube face turns.
Lemma. Orientation checked cycle by cycle [frap-000U]AGENTDRAFTED
Lemma. Orientation checked cycle by cycle [frap-000U]AGENTDRAFTED
Let \(g=(\pi ,a)\) be a framed transport on finitely many positions \(I\), with a faithful local group \(K\) on nonempty \(\Omega \) and bijective local frames. On a cycle
\[i_0\longmapsto i_1\longmapsto \cdots \longmapsto i_{r-1} \longmapsto i_0\]of \(\pi \), the return transport in the first fiber has framed map \(a_{i_{r-1}}\cdots a_{i_1}a_{i_0}\). Its class in \(K_{\mathrm {ab}}\) is that cycle's contribution to \(\chi (g)=\prod _{i\in I}[a_i]\). Consequently, identity return transport on every position cycle implies \(\chi (g)=1\). This is the cycle criterion.
Proof.
Proof.
Apply the coordinate action \(r\) times. Each local map is applied after the preceding one, giving the stated product with the first map on the right. In the abelianization its factors may be reordered; multiplying over disjoint cycles uses each factor exactly once. A fixed position is a cycle of length one and must also be checked.
This is a sufficient test derived from the canonical character of [marchetti2025rubik, Section 3.1, p. 7]. A generator's finite order alone does not make its return map on each shorter position cycle the identity; the local transport on that cycle is the quantity to check.
Example. Corner twists and edge flips on the cube [frap-000V]AGENTDRAFTED
Example. Corner twists and edge flips on the cube [frap-000V]AGENTDRAFTED
Use the unmarked-center, fixed-frame sticker model of one cube face turn. We apply the canonical character of [marchetti2025rubik, Section 3.1, p. 7] to this explicit action. At a corner the three incident sticker directions have a cyclic order inherited from the ambient orientation. Choose bijective cyclic frames at all eight positions. Rotations preserve that order, giving local group \(C_3\); at each of the twelve edges an ordering of its two stickers gives local group \(C_2\). Both actions on the local stickers are faithful. Writing these groups additively, the two characters are
\[\chi _c=\sum _{i=1}^{8}a_i\pmod 3,\qquad \chi _e=\sum _{j=1}^{12}b_j\pmod 2.\]A quarter-turn has one four-cycle of affected corners and one of affected edges. Four applications restore every sticker, so the return transport on each of these cycles is the identity. Every other corner and edge is fixed with identity local transport. The cycle criterion gives \(\chi _c=0\) and \(\chi _e=0\) for every face quarter-turn. The kernel argument extends this to every word in those turns, including inverses and half-turns.
For a concrete cyclic frame, choose any frame at corner \(i_0\) of the upper face and define the next three by transporting it with the shape rotation \(q\). Since \(q^4=1\), all four local factors of this turn become zero. This frame checks that one generator; the frame-independence theorem transfers the conclusion to any fixed choice of cyclic frames used for the other generators.
A configuration with a corner twist of just one corner by \(1\) has \(\chi _c=1\) and is impossible under these moves. Twisting two corners by \(1\) and \(-1\) passes this test, but the calculation alone does not construct a legal sequence. Likewise, flipping exactly one edge fails the second test. An edge flip of exactly one edge therefore fails the second test. Reachability needs additional arguments.
Transfer gives a group-theoretic form of the same frame cancellation and shows how the local group limits what total orientation can detect.
Transfer and the effect of dimension [frap-000B]AGENTDRAFTED
Transfer and the effect of dimension [frap-000B]AGENTDRAFTED
The total-orientation character detects one conservation law, but it does not explain how to compare frames chosen at different positions. The motivating question is how to transport that comparison through a transitive action. Transfer uses the same cancellation as the total-orientation character for coset representatives [mayer2015artin, Sections 3.1--3.3]. The first section identifies the connection through an actual transitive action and its stabilizer; the second computes how the local rotation groups of simplices and cubes change with dimension, following [marchetti2025rubik, Sections 4--5].
Transfer and local orientation [frap-0012]AGENTDRAFTED
Transfer and local orientation [frap-0012]AGENTDRAFTED
Left multiplication permutes the cosets of a finite-index subgroup. Representatives record the motion between cosets, leaving one residual subgroup element at each position. Abelianizing their product gives transfer [mayer2015artin, Sections 3.1--3.3]. Transported frames then identify its local image with the total-orientation character of an action.
Theorem. Finite-index transfer [frap-000W]
Theorem. Finite-index transfer [frap-000W]
Let \(H\leq G\) have finite index. Choose representatives \(r_i\) for the left cosets \(r_iH\), indexed bijectively by a finite set \(I\). For \(g\in G\), left multiplication permutes the cosets, so uniquely write
\[g r_i=r_{\pi _g(i)}h_i(g),\qquad h_i(g)\in H.\]Write \(H_{\mathrm {ab}}=H/[H,H]\) and \([h]\) for the class of \(h\in H\). The abelianization is the target of the transfer
\[T_{G,H}:G\longrightarrow H_{\mathrm {ab}},\qquad T_{G,H}(g)=\prod _{i\in I}[h_i(g)]\]is a homomorphism independent of the chosen representatives. This is the left-coset construction of [mayer2015artin, Definition 3.1, Proposition 3.1 and Theorem 3.1, pp. 4--6]. Neither finiteness of \(G\) nor normality of \(H\) is required.
Proof.
Proof.
We compose left actions rightmost first. Multiplication on cosets gives \(\pi _{gk}=\pi _g\pi _k\). Expanding \(gkr_i\) in two steps yields
\[h_i(gk)=h_{\pi _k(i)}(g)h_i(k).\]Taking classes and multiplying over \(i\) gives \(T_{G,H}(gk)=T_{G,H}(g)T_{G,H}(k)\), because \(\pi _k\) reorders the first factors. Replace \(r_i\) by \(r_i t_i\), with \(t_i\in H\). The new residual factor is \(t_{\pi _g(i)}^{-1}h_i(g)t_i\). Its total class contains each \([t_i]\) and its inverse exactly once, so they cancel. Reindexing the cosets also only reorders an abelian product. This proves independence of all choices.
The linked transfer definitions specialize the homomorphism \(\phi :H\to A\) to the quotient \(H\to H_{\mathrm {ab}}\). The indexed formula takes \(f(i)=r_i\) and \(\pi =\pi _g\); its factor \(r_{\pi _g(i)}^{-1}g r_i\) is precisely \(h_i(g)\). Its finite-index instance follows from the finite bijective family of cosets.
Proposition. Transfer computes total local orientation [frap-000X]AGENTDRAFTED
Proposition. Transfer computes total local orientation [frap-000X]AGENTDRAFTED
Let \(G\) act transitively on a finite nonempty position set \(I\), and on a tagged union of fibers \(X_i\), carrying \(X_i\) bijectively to \(X_{g i}\). Fix \(i_0\in I\) and put \(H=G_{i_0}\). Let \(K\) act faithfully on a nonempty set \(\Omega \); choose a bijective base frame \(c_0:\Omega \to X_{i_0}\) and a homomorphism \(\rho :H\to K\) satisfying \(h c_0=c_0\rho (h)\) for every \(h\in H\). Choose \(r_i\in G\) with \(r_i i_0=i\), and set \(c_i=r_i c_0\). Then the total-orientation character of this framed transport is
\[\chi =\rho _{\mathrm {ab}}\circ T_{G,H}:G\longrightarrow K_{\mathrm {ab}},\]where \(T_{G,H}\) is transfer and \(\rho _{\mathrm {ab}}([h])=[\rho (h)]\). This identifies the coset construction in [mayer2015artin, Section 3.3, p. 6] with the local-frame coordinates of [marchetti2025rubik, Section 3.1, pp. 6--7].
Proof.
Proof.
The map \(G/H\to I\), \(rH\mapsto r i_0\), is a bijection: \(r i_0=s i_0\) exactly when \(s^{-1}r\in H\). Thus \(H\) has finite index \(|I|\), and the \(r_i\) are left-coset representatives. Write \(\pi _g(i)=g i\) and \(g r_i=r_{\pi _g(i)}h_i(g)\). Then
\[g c_i=g r_i c_0=r_{\pi _g(i)}h_i(g)c_0 =c_{\pi _g(i)}\rho (h_i(g)).\]Consequently every local factor belongs to \(K\), and its source-indexed coordinate is \(a_i(g)=\rho (h_i(g))\). A homomorphism sends commutators to commutators, so \(\rho _{\mathrm {ab}}\) is well defined. Multiplying the local classes gives
\[\chi (g)=\prod _i[\rho (h_i(g))] =\rho _{\mathrm {ab}}\left (\prod _i[h_i(g)]\right ).\]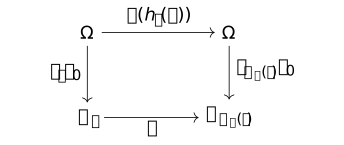
The vertical arrows are the transported frames. The equality \(g r_i=r_{\pi _g(i)}h_i(g)\) makes the square commute: after the destination representative is removed, the remaining motion fixes \(i_0\) and acts through \(\rho \). Changing representatives changes these frames within \(K\), so the character is unchanged.
The induced map is Abelianization.map. Naturality of
transfer is MonoidHom.transfer_comp, with
\(\phi :H\to H_{\mathrm {ab}}\) the quotient map and the target map
\(\rho _{\mathrm {ab}}\). That algebraic identity supports the last
equality; the identification with the actual fiber action is the
transported-frame argument above.
Example. Corner and edge stabilizers of the cube [frap-000Y]AGENTDRAFTED
Example. Corner and edge stabilizers of the cube [frap-000Y]AGENTDRAFTED
Let \(G\) be the actual permutation group generated by the six outer-face quarter-turns of the ordinary cube, with its frame of reference fixed. Use the corner and edge fibers: cyclic corner labels with local group \(C_3\), and edge labels with local group \(C_2\). This specializes the local-orientation construction of [marchetti2025rubik, Section 3.1]; the orbit argument below identifies the stabilizers needed for transfer.
The action on eight corner positions is transitive. Adjacent corners share a face whose quarter-turn takes one to the other, and the cube's edge graph is connected. Hence a corner stabilizer \(H_c\) has index eight. Its action on the three cyclically ordered labels gives a homomorphism \(\rho _c:H_c\to C_3\). The action on twelve edge positions is also transitive: the four edges of one face form a single orbit under its quarter-turn; neighboring faces share an edge; and the face-adjacency graph is connected. Thus an edge stabilizer \(H_e\) has index twelve, with local action \(\rho _e:H_e\to C_2\).
Choose a frame at the fixed corner or edge and transport it using coset representatives. The transfer comparison gives
\[\chi _c=(\rho _c)_{\mathrm {ab}}\circ T_{G,H_c},\qquad \chi _e=(\rho _e)_{\mathrm {ab}}\circ T_{G,H_e}.\]We identify the abelianizations of \(C_3\) and \(C_2\) with those groups. The face-turn calculation proves that the twist and flip characters vanish on every legal generator, hence on \(G\). It follows that these two local images of transfer vanish. It does not follow that \(T_{G,H_c}\) or \(T_{G,H_e}\) is trivial in the larger stabilizer abelianizations. No classification of \(G\) was needed.
Dimension and local rotation groups [frap-0013]AGENTDRAFTED
Dimension and local rotation groups [frap-0013]AGENTDRAFTED
The local corner groups of simplices and cubes are alternating groups. Their commutator subgroups determine the information that survives the total-orientation character [marchetti2025rubik, Sections 4--5].
Proposition. Local rotations of simplices and cubes [frap-000Z]AGENTDRAFTED
Proposition. Local rotations of simplices and cubes [frap-000Z]AGENTDRAFTED
For \(d\geq 3\), a vertex figure of a \(d\)-simplex or a \(d\)-cube is a \((d-1)\)-simplex. Its automorphism group is \(S_d\), and its rotation subgroup is \(A_d\). These are the local corner groups used in [marchetti2025rubik, Section 4, p. 10, and Section 5, p. 14].
Proof.
Proof.
At a vertex of either polytope there are \(d\) incident edges. Faces containing that vertex correspond to subsets of those edges: for a simplex one chooses the other vertices, and for a cube one chooses the coordinate directions in which the face varies. This is the face poset of a simplex on \(d\) vertices, of dimension \(d-1\). An automorphism permutes its vertices, and every vertex permutation extends uniquely to the subsets, giving \(S_d\).
A base flag orders these \(d\) vertices. Its distinguished involutions are adjacent transpositions. They generate \(S_d\), and the even words are precisely the even permutations. Thus the rotation subgroup is \(A_d\).
Here \(d\) is abstract dimension. Varying the layer count of an \(N\times N\times N\) cube leaves the ambient dimension equal to three; it changes the piece orbits and allowed layer moves instead.
Theorem. Abelianizations of the local alternating groups [frap-0010]AGENTDRAFTED
Theorem. Abelianizations of the local alternating groups [frap-0010]AGENTDRAFTED
Let \(A_d\) be the alternating group on \(d\) letters, with composition rightmost first. Then
\[(A_3)_{\mathrm {ab}}\cong C_3,\qquad (A_4)_{\mathrm {ab}}\cong C_3,\qquad (A_d)_{\mathrm {ab}}=1\quad (d\geq 5).\]The corresponding commutator subgroups are stated after Proposition 4.1 in [marchetti2025rubik, Section 4.1, p. 11]. We give the elementary calculation, using \([g,h]=ghg^{-1}h^{-1}\).
Proof.
Proof.
The group \(A_3\) is cyclic of order three, so already abelian. In \(A_4\), let \(V=\{1,(12)(34),(13)(24),(14)(23)\}\). Products and inverses stay in this four-element set, and conjugation permutes its three nonidentity elements. Hence \(V\) is normal. The quotient has order three, so it is cyclic and \([A_4,A_4]\subseteq V\). Direct multiplication gives \([(123),(124)]=(12)(34)\). Conjugating this element by the three-cycle \((123)\) gives the other two double transpositions. The commutator subgroup is normal, so it contains all of \(V\); equality follows.
For \(d\geq 5\), put \(g=(12)(34)\) and \(h=(12)(35)\) in \(A_d\). Multiplication gives \([g,h]=(345)\). Every three-cycle is conjugate to this one within \(A_d\): first choose a conjugating permutation in \(S_d\); if it is odd, compose on the right with a transposition of two symbols outside \(\{3,4,5\}\). This centralizes \((345)\) and changes the parity. Thus the normal subgroup \([A_d,A_d]\) contains every three-cycle.
Three-cycles generate all even permutations. Write an even permutation as a product of an even number of transpositions and pair them. Equal transpositions cancel; two sharing one symbol give a three-cycle; a disjoint pair satisfies \((ab)(cd)=(acb)(acd)\). Hence every pair is a product of three-cycles, proving \([A_d,A_d]=A_d\).
The three cases have separate formalized ingredients.
alternatingGroup.isCyclic_of_card_le_three gives the
cyclicity of \(A_3\). For four letters,
alternatingGroup.kleinFour_eq_commutator identifies \(V\)
with the commutator subgroup, and
TauCeti.card_abelianization_alternatingGroup gives
the quotient's cardinality three; the displayed cyclic isomorphism
then uses the elementary classification of groups of prime order.
For \(d\geq 5\), commutator_alternatingGroup_eq_top is the
perfection statement. These links concern alternating groups, not
the entire puzzle group.
Remark. What the corner character can detect [frap-0011]AGENTDRAFTED
Remark. What the corner character can detect [frap-0011]AGENTDRAFTED
For a \(d\)-simplex or \(d\)-cube with \(d\geq 3\), the local corner groups have rotation subgroup \(A_d\). Their contribution to the total-orientation character passes through \((A_d)_{\mathrm {ab}}\). The abelianization calculation therefore measures exactly what this detector can see, as in [marchetti2025rubik, Section 4.1, p. 11, and equation (19), p. 14].
In dimension three the target is \(C_3\), the familiar corner twist sum. In dimension four the local group has grown to the nonabelian \(A_4\), but the character still sees only a \(C_3\) quotient: every local change in the Klein four group disappears from it. In dimensions five and above the local group is perfect, so this corner character is identically trivial on the ambient framed transports.
A lost detector does not classify the legal moves. Other piece types, permutation signs and the subgroup actually generated by facet turns may still impose constraints. Even when the target is nontrivial, conservation requires a generator check; the local abelianization alone does not supply one.
Notes on formulating theoretical intelligence potential [ftip-0001]
📄PDFAGENTDRAFTED
- August 27, 2026
- Utensil Song
Notes on formulating theoretical intelligence potential [ftip-0001]
📄PDFAGENTDRAFTED
- August 27, 2026
- Utensil Song
Formulating Theoretical Intelligence Potential (FTIP) studies how much reliable capability post-training and agent procedures can obtain from a specified pretrained model, and how that capability depends on information, feedback, computation and evaluation. The question is comparative: what improves, through which mechanism, at what cost, and on which tasks? It concerns behavior under specified conditions, rather than an intrinsic intelligence number assigned to a model.
Post-training studies how demonstrations, preferences, rewards and interaction change a model's policy. Fine-tuning, direct preference optimization, and reinforcement learning with human or verifiable feedback differ in their objectives, feedback and update procedures. Agent systems add another source of change: tool use, search, persistent state and retained context can alter behavior even with fixed model weights. Their computation, failure modes and reliability are part of the capability being studied.
Evaluation and finite limits ask which improvements survive independent testing, what transfers to other task laws, and what follows from assumptions about sampling, support, feedback and proxy error. Architecture and optimization ask how the model's computation, parameterization and optimizer affect achievable capability and resource tradeoffs. Its mechanism map asks which bottleneck a design changes and what evidence would demonstrate that change, without ranking architectures. Matched comparisons connect these questions without identifying a higher training reward, a successful rollout and a transferable capability as the same outcome.
Conceptual discovery across generations extends the study to successive learned artifacts, reusable representations, curricula and contributions from independently developed researchers. It asks when a system can discover a method and acquire the ability to use it on fresh problems, with development and learning costs included. Mathematical research supplies concrete settings for that question; the proposed discovery-cost separation remains open. The chapter's research route makes the capability profile explicit: follow the lineage and acquisition criterion, then use the mathematical research records and assays to separate retrieval, transfer, remix, construction, consequence, verification and retention.
Civilization and economic reproduction ask how learning resources arise from productive capacity, finance and the renewal of knowledge. Economic development can constrain a campaign or expand its future resources. The chapter proves conditional bounds for specified models and studies reliable contributions and shared preparation costs, alongside alternative models that sustain continued learning. These results make the budget part of the mathematical question; the general discovery lower bound remains open.
The shared model, task and evaluation interfaces support these different lines of inquiry. The notes combine published empirical observations, specified mechanisms, finite mathematical results and open research questions. Each result has its own assumptions and scope; a capability claim depends on the starting artifact, the intervention, independent evaluation and resource bounds.
Remark. How to read these notes [ftip-00NW]AGENTDRAFTED
Remark. How to read these notes [ftip-00NW]AGENTDRAFTED
The seven chapters connect learning mechanisms, computational constraints, agent reliability, evaluation, capability growth and economic conditions. The diagram shows their main logical relationships. Solid arrows indicate concepts used by another analysis. The dashed branch supplies architecture-specific detail for comparisons involving a particular model implementation or optimizer. Within that branch, the mechanism map identifies which capability bottleneck changes and what evidence would show the change; the second dashed edge marks its possible consequences for representations and discovery across model generations.
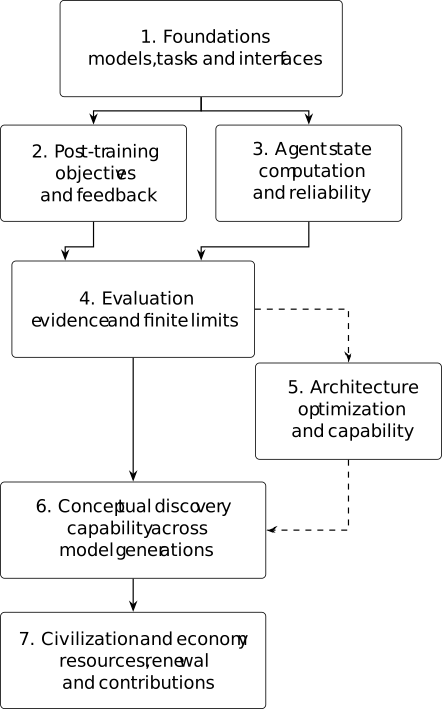
Post-training and agent state are complementary sources of capability change: one changes learned parameters, while the other manages interaction, computation and retained artifacts. Evaluation studies the evidence for those changes and their limits. Architecture analysis connects the comparison to the model's computation and optimization. The lineage analysis extends it to discovery and learning across generations. Economic analysis then asks how productive capacity, knowledge renewal and financing make the required resources available, and how learning changes those conditions.
- Foundations and interfaces introduces capability claims, token probabilities, pretraining, tasks and environments. These interfaces allow the later analysis to specify a model without requiring a particular neural architecture.
- Post-training, alignment, and feedback develops fine-tuning, preference learning, RLHF, DPO, RLVR and agentic training, with concrete objectives, feedback mechanisms and update procedures.
- Agent state, computation, and reliability studies persistent state, retained context, recursive execution, failure modes and reliability. It separates changes to agent behavior from changes to model weights while examining their interaction.
- Evaluation, evidence, and finite limits fixes the comparison law and costs, studies transport to other evaluations, and develops finite results about discovery, support, feedback and proxy error. Its closing synthesis collects the consequences and counterexamples.
- Architecture-conditioned potential and computation begins with a decoder-only Transformer, then uses the mechanism-family map to ask which capability bottleneck a design changes. Its optimization-geometry and matched-compute sections use the evaluation framework to make implementation-specific claims. The core panel is the default comparison path; the adjunct panel supplies optional objective, temporal-dynamics and function-space lenses.
- Conceptual discovery across model generations studies discovery and learning across successive artifacts. It develops the complete lineage, independently developed contributions, representation learning, curricula and mathematical research settings, alongside the conjecture and arguments that could establish or defeat it. Its research route records the capability profile and tests retrieval, transfer, remix, construction, consequence, verification and acquisition as separate outcomes.
- Civilization, economic reproduction and capability conditions learning on feasible economic paths. It develops knowledge renewal and financing bounds, reliable acquisition from contributors, shared preparation costs, and alternative models with different implications for continued learning.
The research question and scope introduces the common distinctions between elicitation, acquisition, computation and evaluation. Questions about fine-tuning, preferences, rewards and interaction lead to the post-training chapter. Questions about memory, tools, recursive execution and reliability lead to the agent chapter. Both use the model, task and environment interfaces in the foundations.
Questions about a particular model implementation or optimizer are developed in the architecture chapter. Begin with its mechanism-family map when the question is which bottleneck a mechanism changes and what evidence could establish the change. Then follow the frontier and protocol route through architecture-indexed ceilings and matched compute, published paired measurements, paired model measurements, conditional frontiers and study design. The shared evaluation framework supplies the task laws and resource comparisons used in that analysis.
A mechanism-first route reads the core panel before the frontier sections. Its adjunct panel is optional: it changes an objective, temporal law or function-space bias and should be compared under the same interfaces rather than treated as another architecture family. Questions about representations, curricula and discovery continue through conceptual discovery; questions about costs, stability, monitorability and transfer return to evaluation and finite limits and its comparison controls.
Claims about a capability gain or limit are examined in independent evaluation and post-training potential and the following finite results and counterexamples. These sections distinguish training reward from evaluation evidence, examine transport to other task laws, and make the assumptions behind a bound explicit. Training, search and deployment costs have distinct roles in those comparisons.
Questions about reusable concepts and capability growth across generations are developed in conceptual discovery. Read its complete lineage and acquisition criterion first; then use the capability profile, semantic discovery records and research assays inside the mathematical research setting. The conjecture and its arguments remain the place to assess the proposed separation, while contributor development, representations and curricula provide distinct settings for it.
Questions about the origin of a learning budget begin with economic state and admissible paths and the uniform resource envelope. The knowledge-renewal model and financing account give distinct constraints; the automation game studies an equilibrium effect under a narrower institutional assumption. The contribution protocol and portfolio comparison specify possible cost advantages. Read these with the alternative mathematical models: they show which maintenance, investment, substitution and simulation assumptions can prevent a proposed separation. Each proved implication is conditional; none alone establishes a universal training ceiling or the open conceptual-discovery lower bound.
Foundations and interfaces [ftip-00J9]AGENTDRAFTED
Foundations and interfaces [ftip-00J9]AGENTDRAFTED
A post-training comparison depends on the model, task, environment, and evaluation interfaces. These determine the possible interactions and the quantities by which their outcomes are compared.
The interfaces here require a token probability law and a specified starting artifact, without fixing the neural computation that implements them. The decoder-only Transformer appears with the later architecture analysis. Pretraining, tasks and interaction provide the shared starting point for both parameter updates and agent adaptation.
Research question and scope [ftip-0002]AGENTDRAFTED
Research question and scope [ftip-0002]AGENTDRAFTED
The question is how much independently evaluated capability a specified learning system can develop from its starting model, information and tools under stated resource bounds. Post-training changes model parameters using examples, comparisons, rewards or interaction. Agent procedures also change contexts, search and retained experience. Their effects depend on the tasks, available feedback, model computation and evaluation procedure.
A score increase can have several explanations. Elicitation improves access to behavior already observable under the starting procedure. Acquisition requires improvement on an independent transfer evaluation. More deployment computation can improve performance through additional search or sampling, while exploitation of an evaluator can improve its score without improving the intended capability. The conventions below distinguish these possibilities.
The post-training questions concern what different objectives, update rules and feedback sources enable a model to learn. The agent questions concern what persistent state, tools, interaction and recursive computation enable a system to do reliably. A retained library and an updated set of model weights can both affect later performance, but they are different interventions with different costs.
Architecture-dependent questions concern how token probabilities are computed, how parameterization interacts with optimization, and how model implementations compare under matched resources. Evaluation determines which comparisons the evidence supports. Finite probability bounds, counterexamples and feedback analyses establish consequences under their stated conditions; they do not by themselves bound every possible learning procedure.
The same distinctions extend to successive model generations. An autonomous lineage may change its representations, curricula and research procedures; an independently developed contribution may change what it can affordably acquire. That comparison includes both development and learning by the system receiving the contribution. The mathematical research settings study this direction within the broader capability question. A plateau in one recipe is evidence about that recipe, and the general discovery-cost separation remains a conjecture.
Economic conditions extend resource accounting to the productive stocks, institutions and allocations that sustain learning. Physical feasibility, financing, knowledge maintenance and competitive equilibrium impose different restrictions. A bound on attainable resources must cover the admitted development policies, including investment and deliberate maintenance. Such a bound becomes decisive for capability only when combined with an independent work lower bound; a contributor advantage also needs a realizable acquisition protocol under the same constraints.
Convention. Capability claims, procedures, evaluations, and resource bounds [ftip-0003]AGENTDRAFTED
Convention. Capability claims, procedures, evaluations, and resource bounds [ftip-0003]AGENTDRAFTED
A capability claim in this note names four objects:
- a starting model artifact \(M_0\), with its accompanying information, libraries, tools and initially available controllers disclosed;
- a procedure \(A\) that may query models, interact, retain experience and train successor artifacts, with its feedback sources specified;
- an evaluation rule \(E\), including the task law, retained artifact and deployment procedure being evaluated; and
- a resource bound \(b\).
The claim concerns the observable outcome of running \(A\) from \(M_0\) and judging the result with \(E\) while respecting \(b\). It is not a claim about an unbounded or unspecified model.
For a comparison across generations, use the complete lineage specification to make these initial resources and permitted operations explicit. Newly generated controllers and learned artifacts belong to the charged process. An externally supplied contribution has a declared producer and acquisition procedure; it is not silently added to the starting model's resources.
The bound \(b\) may contain several coordinates, such as training tokens, rollouts, accelerator work, wall-clock time, tool calls, or evaluation-time samples. Distinguish the complete development budget from the deployment budget used to compare frozen artifacts on fresh problems. Coordinates with different units remain separate unless a declared cost model converts them to a common unit.
This convention follows the experimental separation between training and inference procedures used in [shao2024deepseekmath, secs. 3--4] and [guo2025deepseek, secs. 2--3]. Those studies motivate the objects in a claim; they do not imply that every capability is summarized by one benchmark or one scalar budget.
Example. Same model under two procedures and budgets [ftip-0004]AGENTDRAFTED
Example. Same model under two procedures and budgets [ftip-0004]AGENTDRAFTED
Holding the model fixed, the comparison isolates how inference procedure and budget alter measured success.
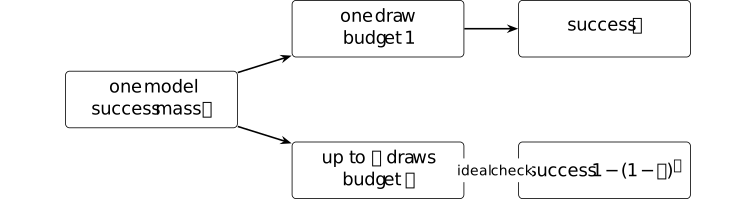
Assume independent draws and a declared perfect checker that recognizes a correct candidate when one appears. The one-draw procedure succeeds with \(J_1=p\). A procedure allowed up to \(k\) draws succeeds whenever not all draws fail: \[ J_k=1-(1-p)^k. \] Both procedures query the same conditional distribution.
Policy performance under a specified interaction and evaluation procedure is standard in [sutton2018reinforcement, Section 3.5]. The formula demonstrates procedural dependence. Independence and a perfect checker are declared toy assumptions, not properties attributed to a frontier language model.
Definition. Elicitation [ftip-0005]AGENTDRAFTED
Definition. Elicitation [ftip-0005]AGENTDRAFTED
Fix a capability claim in Convention [ftip-0003], a prespecified successful behaviour event \(B\), and a tolerance \(\varepsilon >0\). Let \(p_0(B)\) be the probability of \(B\) under the declared starting procedure and \(p_1(B)\) its probability after the intervention, both measured by the same evaluator. An elicitation witness is an observed increase \[ p_1(B)>p_0(B)\quad \text {with}\quad p_0(B)\geq \varepsilon . \] It witnesses improved access to behaviour that was already observable at the declared starting budget.
The event \(B\), tolerance \(\varepsilon \), sampling procedure, and confidence rule are part of the claim. Changing any of them changes what the witness means.
Remark. Elicitation, starting probability, and finite evidence [ftip-0006]AGENTDRAFTED
Remark. Elicitation, starting probability, and finite evidence [ftip-0006]AGENTDRAFTED
Reinforcement learning can move probability toward successful traces that a base model already emits; this possibility is tested empirically in [liu2025understanding, secs. 2.3 and 3.3--3.4]. A finite experiment cannot establish that an unrestricted generative model assigns exactly zero probability to a behaviour. The positive threshold \(\varepsilon \) therefore belongs to the declared experiment rather than to an ontological claim about what the model ``contains.''
An elicitation witness depends on the sampling budget, decoding rule, and reward. Bounding the attainable increase in \(p_1(B)\) requires assumptions about the starting probability \(p_0(B)\) and the information supplied by post-training.
Definition. Capability acquisition [ftip-0007]AGENTDRAFTED
Definition. Capability acquisition [ftip-0007]AGENTDRAFTED
Fix a capability claim in Convention [ftip-0003], a prespecified transfer evaluation \(E^{+}\), and thresholds \(0\leq \varepsilon _0<\varepsilon _1\leq 1\). Let \(u_0\) and \(u_1\) be the probabilities of passing \(E^{+}\) before and after the intervention, using the same evaluation protocol and budget. An acquisition witness is the pair of inequalities \[ u_0\leq \varepsilon _0 \qquad \text {and}\qquad u_1\geq \varepsilon _1. \] The transfer evaluation must not be used to select training examples, rewards, or checkpoints.
An acquisition witness is operational. It records a large, independently measured change under one declared procedure; it does not prove that the starting model assigned mathematical probability zero to every successful continuation.
Remark. A transfer contrast as evidence of acquisition [ftip-0008]AGENTDRAFTED
Remark. A transfer contrast as evidence of acquisition [ftip-0008]AGENTDRAFTED
Training success alone does not distinguish learning from memorization, selection, or evaluator exploitation. The base-versus-reinforcement-learning comparisons in [yue2025does, secs. 3--5] motivate this distinction, but their empirical criteria are not a universal definition of acquisition.
The thresholds in Definition [ftip-0007] require enough evaluation samples to certify both inequalities. Whether the witness survives a distribution shift depends on the task law; evaluator leakage invalidates its interpretation as independent evidence.
Tokens, text, and probability [ftip-0009]AGENTDRAFTED
Tokens, text, and probability [ftip-0009]AGENTDRAFTED
A language model assigns probabilities to tokens rather than directly to semantic answers. We therefore fix the elementary probability notation, the text-to-token interface, and the factorization of a continuation before describing the neural computation that realizes those probabilities.
Notation. Finite sets, maps, distributions, random variables, and expectation [ftip-000A]AGENTDRAFTED
Notation. Finite sets, maps, distributions, random variables, and expectation [ftip-000A]AGENTDRAFTED
For a finite set \(X\), write \(|X|\) for its cardinality and \(X^*\) for the set of finite sequences with entries in \(X\). A map \(f:X\to Y\) sends \(x\in X\) to \(f(x)\in Y\); the inverse image of \(A\subseteq Y\) is \(f^{-1}(A)=\{x\in X:f(x)\in A\}\).
Write \[ \Delta (X)=\left \{p:X\to [0,1]:\sum _{x\in X}p(x)=1\right \} \] for the probability simplex on \(X\). If \(p\in \Delta (X)\) and \(Z:X\to \mathbb R\), then \[ \mathbb E_{x\sim p}[Z(x)]=\sum _{x\in X}p(x)Z(x). \] A random variable is a map from the sample set to its value set. Random variables \(Z\) and \(W\) are independent under \(p\) when \(p(Z=z,W=w)=p(Z=z)p(W=w)\) for every pair of values \(z,w\).
For nonfinite interaction spaces, probability laws and conditional kernels require the measurable structure described in Remark [ftip-000C].
Definition. Finite probability law [ftip-000B]AGENTDRAFTED
Definition. Finite probability law [ftip-000B]AGENTDRAFTED
Using the notation of Notation [ftip-000A], a finite probability law on \(X\) is an element \(p\in \Delta (X)\). For an event \(A\subseteq X\), its probability is \[ p(A)=\sum _{x\in A}p(x). \] For \(p(A)>0\), the conditional law on \(B\subseteq X\) is \(p(B\mid A)=p(A\cap B)/p(A)\).
Remark. Finite and measurable probability laws [ftip-000C]AGENTDRAFTED
Remark. Finite and measurable probability laws [ftip-000C]AGENTDRAFTED
A finite vocabulary and a bounded token sequence admit probability laws expressed as ordinary sums, with explicit normalization and conditioning. The finite-sequence interface matches [phuong2022formal, sec. 3, Sequence modelling].
States, observations, and tool outputs need not be finite. In that setting \(\Delta (X)\) is replaced by probability measures on a declared measurable space and conditional laws are probability kernels. Results on finite spaces need additional measurable-space hypotheses before they apply in this setting.
Definition. Finite vocabulary [phuong2022formal, sec. 3, Sequence modelling] [ftip-000D]AGENTDRAFTED
Definition. Finite vocabulary [phuong2022formal, sec. 3, Sequence modelling] [ftip-000D]AGENTDRAFTED
A finite vocabulary is a nonempty finite set \(\mathcal V\) of token identifiers. A token identifier is an atomic symbol for the sequence model; it need not be a word or a character.
When termination is represented in-band, choose a distinguished token \(\mathtt {eos}\in \mathcal V\). Other control tokens, if present, are named as elements of the same vocabulary rather than assumed implicitly.
Definition. Tokenizer and detokenizer [kudo2018sentencepiece, secs. 3.1 and 3.5] [ftip-000E]AGENTDRAFTED
Definition. Tokenizer and detokenizer [kudo2018sentencepiece, secs. 3.1 and 3.5] [ftip-000E]AGENTDRAFTED
Let \(\Sigma \) be a finite character or byte alphabet and let \(\mathcal V\) be the vocabulary of Definition [ftip-000D]. A tokenizer is a specified map \(\tau :\Sigma ^*\to \mathcal V^*\). A detokenizer is a specified map \(\delta :\mathcal V^*\to \Sigma ^*\).
A tokenizer package also fixes its text normalization rule \(N\). When the package promises normalized round trips, the relevant condition is \(\delta (\tau (s))=N(s)\) for text \(s\in \Sigma ^*\); it is not the claim that \(\tau \) and \(\delta \) are inverse bijections on all sequences. SentencePiece keeps the segmentation model and detokenization convention together, which is why both maps belong to the model interface.
Byte-pair encoding gives another construction of \(\tau \). Learned merge operations turn an initial symbol sequence into subword units; see [sennrich2016neural, §3.2]. The learned merges and base alphabet are therefore part of the tokenizer specification.
Example. A tokenizer round trip and normalization failure [ftip-000F]AGENTDRAFTED
Example. A tokenizer round trip and normalization failure [ftip-000F]AGENTDRAFTED
A four-stage toy tokenizer separates token-level round-trip stability from recovery of the original string.

Here underscores display spaces. Declare \(N(A\_\_B)=a\_b\), \(T(a\_b)=(a,b)\), and \(D(a,b)=a\_b\). For \(s=A\_\_B\), \[ D(T(N(s)))=a\_b\neq s, \qquad T(N(D(T(N(s)))))=(a,b). \] The token sequence is stable after normalization although the original case and repeated space are not recovered.
The source-grounded tokenizer interface is Definition [ftip-000E]. The displayed normalization rule belongs only to this finite construction; no such lossy transformation is attributed to SentencePiece.
Convention. Token sequences, prefixes, positions, and end-of-sequence [ftip-000G]AGENTDRAFTED
Convention. Token sequences, prefixes, positions, and end-of-sequence [ftip-000G]AGENTDRAFTED
Let \(\mathcal V\) be the vocabulary of Definition [ftip-000D]. A token sequence of length \(n\geq 0\) is written \(x_{1:n}=(x_1,\ldots ,x_n)\in \mathcal V^n\); positions are one-based. Its length is \(|x_{1:n}|=n\), its prefix before position \(t\) is \(x_{<t}=x_{1:t-1}\), and \(x_{<1}\) is the empty sequence. Juxtaposition \(xy\) denotes concatenation.
If \(\mathtt {eos}\) is distinguished, a completed generated continuation \(y_{1:m}\) ends with \(y_m=\mathtt {eos}\) and contains no earlier \(\mathtt {eos}\). A fixed length limit can also stop generation; the stopping mechanism must state which convention it uses.
Definition. Conditional next-token law [phuong2022formal, sec. 3, Sequence modelling] [ftip-000H]AGENTDRAFTED
Definition. Conditional next-token law [phuong2022formal, sec. 3, Sequence modelling] [ftip-000H]AGENTDRAFTED
Let \(\Theta \) be a parameter set. With the probability notation of Notation [ftip-000A] and the sequence convention of Convention [ftip-000G], a conditional next-token law is a family of maps \[ \pi _\theta :\mathcal V^*\longrightarrow \Delta (\mathcal V), \qquad \theta \in \Theta . \] For a prefix \(x_{<t}\) and token \(a\in \mathcal V\), the number \(\pi _\theta (a\mid x_{<t})\) is the probability assigned to choosing \(a\) at position \(t\).
This is the observable probabilistic interface. It does not yet specify the neural computation that produces the distribution.
Definition. Autoregressive continuation law [phuong2022formal, sec. 3, Sequence modelling] [ftip-000I]AGENTDRAFTED
Definition. Autoregressive continuation law [phuong2022formal, sec. 3, Sequence modelling] [ftip-000I]AGENTDRAFTED
Fix the next-token law of Definition [ftip-000H], a prompt \(x\in \mathcal V^*\), and a continuation \(y_{1:m}\in \mathcal V^m\). Its autoregressive continuation probability is \[ P_\theta (y_{1:m}\mid x) =\prod _{t=1}^{m} \pi _\theta \left (y_t\mid x y_{<t}\right ). \] Each factor conditions only on the prompt and earlier continuation tokens.
If generation stops on \(\mathtt {eos}\), the law of a completed continuation is restricted to the sequences specified in Convention [ftip-000G]. If generation instead stops at a length limit, the terminal event and its probability must be recorded separately.
Example. A three-symbol autoregressive continuation [ftip-000J]AGENTDRAFTED
Example. A three-symbol autoregressive continuation [ftip-000J]AGENTDRAFTED
Along one branch of a three-symbol prefix tree, conditional token laws determine both continuation probability and negative log-likelihood.

Let the vocabulary be \(\{a,b,\mathtt {EOS}\}\) and let \(p_i\) be the displayed conditional probability at step \(i\). The continuation \((b,a,\mathtt {EOS})\) has \[ \Pr (b,a,\mathtt {EOS}\mid a) =p_1p_2p_3, \qquad -\log \Pr =-\sum _{i=1}^{3}\log p_i. \]
The multiplication follows the causal product in [phuong2022formal, Section 3]. Its scope is one fixed finite continuation, leaving both the decoding algorithm and the law over all variable-length outputs unspecified.
Pretraining [ftip-0014]AGENTDRAFTED
Pretraining [ftip-0014]AGENTDRAFTED
Pretraining fits the parameters of a language model to a large corpus by predicting tokens from preceding tokens. This description leaves the data law, window sampler, loss mask, population objective, finite-sample objective, and update rule unspecified. Each receives a separate definition below.
Notation. Pretraining data, masks, parameters, and updates [ftip-0015]AGENTDRAFTED
Notation. Pretraining data, masks, parameters, and updates [ftip-0015]AGENTDRAFTED
Let \(\mathcal D_{\rm doc}\) be a measurable document space and \(\mathcal S\) a finite set of data sources. Source \(s\in \mathcal S\) has a document law \(Q_s\) on \(\mathcal D_{\rm doc}\), and mixture weights \(\alpha \in \Delta (\mathcal S)\) use the simplex notation of Notation [ftip-000A]. Let \(T\) be the context length. A token window is \(x_{1:T}\in \mathcal V^T\); a prediction mask is \(m_{1:T}\in \{0,1\}^T\), where \(m_t=1\) means that the token at position \(t\) contributes to the loss.
Let \(\Theta \) be the parameter set used by the next-token law in Definition [ftip-000H]. The model parameters at optimizer update \(k\in \{0,1,\ldots ,K\}\) are \(\theta _k\in \Theta \); \(\theta _0\) is the initialization and \(\theta _K\) the stopped parameter value. A minibatch at update \(k\) is \(\mathcal B_k\). Random document draws, window offsets, masks, batch order, and optimizer noise are part of the training run even when the notation suppresses them.
Definition. Pretraining source mixture [ftip-0016]AGENTDRAFTED
Definition. Pretraining source mixture [ftip-0016]AGENTDRAFTED
Using Notation [ftip-0015], a pretraining source mixture is the pair \(((Q_s)_{s\in \mathcal S},\alpha )\). It induces the document law \[ Q_{\alpha }(A)=\sum _{s\in \mathcal S}\alpha _s Q_s(A) \] for every document event \(A\): first sample a source \(s\) with probability \(\alpha _s\), then sample a document from \(Q_s\).
The mixture weights specify sampling frequency. They need not equal the fraction of bytes stored in each source. Resampling, epoch boundaries, or temperature-based weights must therefore be recorded as part of \(\alpha \) or its schedule.
Definition. Document filter [ftip-0070]AGENTDRAFTED
Definition. Document filter [ftip-0070]AGENTDRAFTED
Let \(\dagger \) denote rejection. A document filter is a declared map \[ F:\mathcal D_{\rm doc}\longrightarrow \mathcal D_{\rm doc}\cup \{\dagger \}. \] It may retain a document, return a transformed document, or reject it. The lift \(F_{\#}\) applies \(F\) to a finite corpus and removes every \(\dagger \).
A filter specification includes the features it reads, thresholds, transformation rules, and implementation revision. An acceptance rate alone does not determine the retained document law.
Definition. Deduplication operator [ftip-0071]AGENTDRAFTED
Definition. Deduplication operator [ftip-0071]AGENTDRAFTED
Let \(\mathcal M_{\rm doc}\) be the set of finite multisets of documents. A deduplication operator is a map \[ D:\mathcal M_{\rm doc}\longrightarrow \mathcal M_{\rm doc} \] that selects retained representatives according to a declared duplicate relation. The relation may compare complete documents or spans.
The declaration includes normalization, similarity threshold, cluster construction, and representative tie-breaking. Different choices can remove different training events even when they report the same duplicate rate.
Definition. Evaluation decontamination operator [ftip-0072]AGENTDRAFTED
Definition. Evaluation decontamination operator [ftip-0072]AGENTDRAFTED
For a protected evaluation collection \(\mathcal E\), an evaluation decontamination operator is a map \[ C_{\mathcal E}:\mathcal M_{\rm doc}\longrightarrow \mathcal M_{\rm doc} \] that removes documents or spans matching \(\mathcal E\) under a declared matching rule.
The protected collection, normalization, match granularity, threshold, and removal policy are part of the operator. Decontamination against one released benchmark does not establish independence from every related task.
Definition. Ordered pretraining data pipeline [ftip-0017]AGENTDRAFTED
Definition. Ordered pretraining data pipeline [ftip-0017]AGENTDRAFTED
Let \(\mathcal C_{\mathrm {raw}}\in \mathcal M_{\rm doc}\) be a finite corpus drawn from the source mixture in Definition [ftip-0016]. Using the declared document filter, deduplication operator, and evaluation decontamination operator, an ordered pretraining data pipeline returns \[ \mathcal C_{\mathrm {clean}} =C_{\mathcal E}\left (D\left (F_{\#}(\mathcal C_{\mathrm {raw}})\right )\right ). \] Changing the order can change the retained corpus. The pipeline therefore records the order and exact revisions in addition to the three operators.
Remark. From a data pipeline to a corpus law [ftip-0018]AGENTDRAFTED
Remark. From a data pipeline to a corpus law [ftip-0018]AGENTDRAFTED
The source mixture and cleaning pipeline determine different parts of the data law. The mixture in Definition [ftip-0016] describes how raw documents are proposed. The construction in Definition [ftip-0017] determines which proposals survive and how they are transformed. Together with all random seeds and thresholds, they induce a cleaned document law \(Q_{\mathrm {clean}}\).
Kaplan et al. describe the concrete WebText2 dataset in [kaplan2020scaling, sec. 2.3]. Hoffmann et al. report the MassiveText sources and mixture in [hoffmann2022training, Appendix A, Table A1]. A finite released corpus is one realization of such choices, and an undocumented change in them is not identified by a loss--compute curve.
Definition. Context-window sampler [ftip-0019]AGENTDRAFTED
Definition. Context-window sampler [ftip-0019]AGENTDRAFTED
Fix the context length \(T\) from Notation [ftip-0015]. A context-window sampler draws cleaned text from the law described in Remark [ftip-0018] and tokenizes it with Definition [ftip-000E]. It then chooses a declared offset and returns a length-\(T\) token sequence \(x_{1:T}\) together with metadata that identifies document boundaries.
If fewer than \(T\) tokens remain, the sampler must specify whether it pads, drops the suffix, or joins another document. These choices change both the distribution of contexts and the prediction mask.
Definition. Sequence packing and document mask [ftip-001A]AGENTDRAFTED
Definition. Sequence packing and document mask [ftip-001A]AGENTDRAFTED
A packed training record is a tuple \(\zeta =(x,m,c,M^{\mathrm {doc}})\). It places tokenized segments \(x^{(1)},\ldots ,x^{(r)}\) into the length-\(T\) token array \(x\), records a prediction mask \(m\), and records a segment identifier \(c_t\in \{0,1,\ldots ,r\}\) at each position. The value \(c_t=0\) denotes padding. Its document mask is \[ M^{\mathrm {doc}}_{ts}= \begin {cases} 0,&c_t=c_s\ne 0\text { and }s\leq t,\\ -\infty ,&\text {otherwise}. \end {cases} \] Replacing the causal mask in Definition [ftip-000S] by this mask prevents one packed document from attending to another. We write \(x_t(\zeta )\), \(m_t(\zeta )\), and \(M^{\mathrm {doc}}(\zeta )\) for the corresponding fields.
The prediction mask \(m_t(\zeta )\) from Notation [ftip-0015] is one only at positions whose target token is retained for training. Padding, a segment's first token when no predecessor is present, and any deliberately excluded control token receive mask value zero.
Remark. Window sampling, document masks, and packing [ftip-006K]AGENTDRAFTED
Remark. Window sampling, document masks, and packing [ftip-006K]AGENTDRAFTED
[kaplan2020scaling], Section 2.2, uses fixed-length sequence batches.
[phuong2022formal], Section 7, gives the causal language-model objective.
The proposed data interface additionally specifies the sampler, segment identifiers, document mask, and prediction mask. Those boundary choices are not determined by the high-level training accounts.
These objects describe one admissible data interface. A concrete training run must replace them with its offset, padding, joining, masking, and packing rules.
Definition. Token negative log-likelihood [ftip-001B]AGENTDRAFTED
Definition. Token negative log-likelihood [ftip-001B]AGENTDRAFTED
Let \(\zeta =(x,m,c,M^{\mathrm {doc}})\) be a packed training record from Definition [ftip-001A]. Write \(\pi _{\theta ,M^{\mathrm {doc}}(\zeta )}(\,\cdot \mid x_{<t}(\zeta ))\) for the next-token law of Definition [ftip-000H] when every decoder attention layer uses the declared document mask. For a predicted position \(t\geq 2\), its masked token negative log-likelihood is \[ \ell _t(\theta ;\zeta ) =-m_t(\zeta )\log \pi _{\theta ,M^{\mathrm {doc}}(\zeta )} \left (x_t(\zeta )\mid x_{<t}(\zeta )\right ), \] A masked position has zero contribution; an unmasked position penalizes the log probability computed under the same segment boundaries that defined the packed example.
Definition. Population pretraining objective [ftip-001C]AGENTDRAFTED
Definition. Population pretraining objective [ftip-001C]AGENTDRAFTED
Let \(Q_T\) be the law of packed examples induced by Remark [ftip-0018]--Definition [ftip-001A], and assume that its expected number of predicted positions is positive. The population pretraining objective is the expected total token loss divided by the expected number of predicted tokens: \[ L_{\mathrm {pop}}(\theta ) =\frac { \mathbb E_{\zeta \sim Q_T} \left [\sum _{t=2}^{T}\ell _t(\theta ;\zeta )\right ] }{ \mathbb E_{\zeta \sim Q_T} \left [\sum _{t=2}^{T}m_t(\zeta )\right ] }, \] using expectation as fixed in Notation [ftip-000A].
Example. Packing two documents without cross-document attention [ftip-001D]AGENTDRAFTED
Example. Packing two documents without cross-document attention [ftip-001D]AGENTDRAFTED
Packing documents into one row requires a block-causal mask so that each token attends only within its own document and to earlier positions there.

For a packed row, set \(M_{ij}=0\) only when tokens \(i,j\) belong to the same document and \(j\leq i\); otherwise set \(M_{ij}=-\infty \). Thus a token in document \(B\) cannot inspect any token in document \(A\), even when \(A\) precedes \(B\) in storage.
The within-document triangle instantiates the causal mask in Definition [ftip-000S]. The block boundary instantiates the packing convention in Definition [ftip-001A]. Document-isolated attention is the declared convention in this packed row, not a universal description of pretraining systems.
Definition. Empirical pretraining objective [ftip-001E]AGENTDRAFTED
Definition. Empirical pretraining objective [ftip-001E]AGENTDRAFTED
For a finite training sample of packed records \(\mathcal D_N=(\zeta ^{(i)})_{i=1}^{N}\) with at least one unmasked target token, the empirical pretraining objective is \[ L_N(\theta ) =\frac { \sum _{i=1}^{N}\sum _{t=2}^{T} \ell _t(\theta ;\zeta ^{(i)}) }{ \sum _{i=1}^{N}\sum _{t=2}^{T}m_t(\zeta ^{(i)}) }. \] This is a per-predicted-token average. Reusing or resampling examples changes the stochastic optimization path even when the displayed finite-sample function is unchanged.
Remark. Normalization of masked pretraining loss [ftip-006L]AGENTDRAFTED
Remark. Normalization of masked pretraining loss [ftip-006L]AGENTDRAFTED
The autoregressive token loss follows [phuong2022formal, Section 7]. Kaplan et al. report language-model loss with parameter and compute variables in [kaplan2020scaling, sec. 2.1]. The population ratio-of-expectations in Definition [ftip-001C] and finite per-token ratio in Definition [ftip-001E] are proposed normalization conventions with explicit prediction masks. Neither cited source defines those exact ratios.
A theorem or experiment using another record weighting, length weighting, or expectation order must state that change rather than reuse these symbols.
Definition. Minibatch gradient estimator [ftip-001G]AGENTDRAFTED
Definition. Minibatch gradient estimator [ftip-001G]AGENTDRAFTED
At update \(k\), let \(\mathcal B_k\) be the minibatch named in Notation [ftip-0015], and let \(N_k=\sum _{\zeta \in \mathcal B_k}\sum _{t=2}^{T}m_t(\zeta )\) be its number of predicted tokens. For \(N_k>0\), the minibatch gradient estimator is \[ g_k=\frac 1{N_k} \sum _{\zeta \in \mathcal B_k}\sum _{t=2}^{T} \nabla _\theta \ell _t(\theta _k;\zeta ), \] where \(\ell _t\) is defined in Definition [ftip-001B]. Whether \(g_k\) is unbiased for the gradient of Definition [ftip-001C] depends on the window sampler and minibatch weighting. Other sampling schemes require their own bias statement.
Example. A two-record pretraining loss and minibatch estimate [ftip-001F]AGENTDRAFTED
Example. A two-record pretraining loss and minibatch estimate [ftip-001F]AGENTDRAFTED
Two equal-length records make a full empirical loss directly comparable with a minibatch estimate, while exposing the assumptions behind unbiasedness.
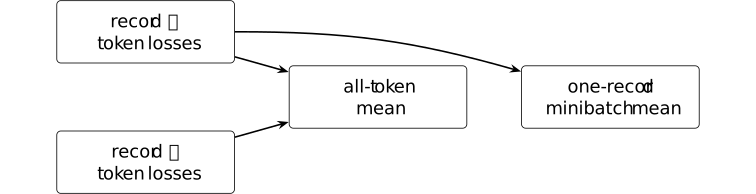
Let \(\ell _{ij}\) denote the token loss at position \(j\) of record \(i\). The full token-average loss is the mean of all \(\ell _{ij}\), while a one-record minibatch averages only the losses from its sampled record. Uniform sampling of equal-length records makes the latter unbiased for the former.
The preceding loss and estimator definitions apply to this equal-length record setup. Equal record lengths make the estimator unbiased here; unequal lengths, padding, dependence, and optimizer noise remain outside its scope.
Definition. Optimizer state [kingma2015adam, Algorithm 1] [ftip-001H]AGENTDRAFTED
Definition. Optimizer state [kingma2015adam, Algorithm 1] [ftip-001H]AGENTDRAFTED
An optimizer state \(s_k\) is the collection of persistent variables, other than the model parameters \(\theta _k\), that an update rule uses after step \(k\). For Adam, \(s_k\) contains the step index and exponential moving averages of the gradient and squared gradient.
The state is initialized by a declared value \(s_0\). Two runs with the same checkpoint \(\theta _k\) but different optimizer states need not have the same next update.
Definition. Parameter update [kingma2015adam, Algorithm 1] [ftip-001I]AGENTDRAFTED
Definition. Parameter update [kingma2015adam, Algorithm 1] [ftip-001I]AGENTDRAFTED
A parameter update rule is a specified map \(U_k\) that takes the current parameters \(\theta _k\), optimizer state \(s_k\), gradient estimate \(g_k\), and scheduled hyperparameters \(\eta _k\), and returns \[ (\theta _{k+1},s_{k+1}) =U_k(\theta _k,s_k,g_k,\eta _k). \] The learning rate, momentum coefficients, numerical stabilizers, clipping, and weight decay belong to \(\eta _k\) or to the declared form of \(U_k\); they are not determined by the loss alone.
Remark. Randomness, schedules, and stopping [ftip-001J]AGENTDRAFTED
Remark. Randomness, schedules, and stopping [ftip-001J]AGENTDRAFTED
A pretraining run is not determined by minimization of the empirical objective \(L_N\) in Definition [ftip-001E]. It includes the initialization, data order, window offsets, dropout and other model randomness, numerical precision, distributed reduction order, optimizer state, every hyperparameter schedule, and a stopping rule. These objects determine a distribution over final parameters even when the source mixture and nominal objective agree.
The training configuration of [vaswani2017attention, sec. 5.3] and the scaling experiments of [kaplan2020scaling, sec. 2.2] report concrete instances of these choices. An optimization result depends on which randomness it averages over and whether the stopping time is fixed or data-dependent.
Definition. Base-model artifact [ftip-001K]AGENTDRAFTED
Definition. Base-model artifact [ftip-001K]AGENTDRAFTED
A base-model artifact is an executable tuple \[ M_0=(\tau ,\delta ,\mathsf {cfg},\theta _K,\mathsf {num}), \] where \(\tau ,\delta \) are the tokenizer and detokenizer of Definition [ftip-000E]; \(\mathsf {cfg}\) fixes the architecture of Definition [ftip-0012]; \(\theta _K\) is the stopped pretraining checkpoint; and \(\mathsf {num}\) fixes the numerical and inference conventions required to evaluate its next-token law.
The tokenizer model is part of the executable system by Definition [ftip-000E]. A weight file without its vocabulary, architecture configuration, or output convention does not determine the law \(\pi _{\theta _K}\) in Definition [ftip-000H]. Training-data and optimizer provenance may accompany the artifact, but they are not runtime inputs.
Remark. The runtime ingredients of a model artifact [ftip-006M]AGENTDRAFTED
Remark. The runtime ingredients of a model artifact [ftip-006M]AGENTDRAFTED
Section 6 of [phuong2022formal] describes decoder architecture. Sections 3.1 and 3.5 of [kudo2018sentencepiece] treat the tokenizer as a separate model. Public model releases additionally distribute weights, configuration, and numerical conventions. The proposed artifact model in Definition [ftip-001K] includes these runtime ingredients because none alone determines an executable next-token law.
Training provenance accompanies the artifact but is not itself a runtime argument. Later causal claims must distinguish the executable endpoint from the process that produced it.
Example. Anatomy of a base-model artifact and V4 optimizer/data provenance [ftip-001L]AGENTDRAFTED
Example. Anatomy of a base-model artifact and V4 optimizer/data provenance [ftip-001L]AGENTDRAFTED
An executable-artifact manifest separates runtime components from evidence about how the corresponding weights were trained.
The pinned DeepSeek-V4-Flash-0731 configuration [⧉] declares architecture and numeric-format fields. Sections 2.4 and 4 of the V4 family report [⧉] describe a mixed Muon/AdamW optimizer allocation and pretraining data construction. The exact 0731 data mixture, optimizer schedule, and post-preview training delta remain undisclosed by those sources.
Tasks and evaluation interfaces [ftip-001M]AGENTDRAFTED
Tasks and evaluation interfaces [ftip-001M]AGENTDRAFTED
A model does not have a benchmark score without a task distribution, an inference procedure, and an evaluator. Keeping these objects separate is essential for post-training: a training change and an evaluation-time search change can raise the same reported score while answering different research questions.
Notation. Tasks, task laws, inference protocols, and utility [ftip-001N]AGENTDRAFTED
Notation. Tasks, task laws, inference protocols, and utility [ftip-001N]AGENTDRAFTED
Write \(\mathsf T\) for a task interface, \(\mathcal X_{\mathsf T}\) for its instance set, and \(\mathcal O_{\mathsf T}\) for its candidate-outcome set. A task instance is \(x\in \mathcal X_{\mathsf T}\) and a candidate outcome is \(o\in \mathcal O_{\mathsf T}\). The symbol \(\mu _{\mathsf T}\) denotes a probability law on instances. Equip the instance and outcome sets with declared sigma-algebras; \(\mu _{\mathsf T}\) is a probability measure on the instance sigma-algebra.
Fix an evaluation-resource dimension \(m_{\mathrm {eval}}\geq 1\) and write \(\mathcal B_{\mathrm {eval}}=\mathbb R_+^{m_{\mathrm {eval}}}\) with its coordinatewise order. An evaluation inference protocol is written \(\mathsf I\); its declared evaluation budget is \(b_{\mathrm {eval}}\in \mathcal B_{\mathrm {eval}}\). Its inference-seed set is \(\Omega _I\), with realized seed \(\xi \in \Omega _I\). An evaluator's random-seed set is \(\Omega _E\); its realized seed is \(\omega \in \Omega _E\). It returns utility \(u_{\mathsf T}(x,o;\omega )\in \mathbb R^d\). The dimension \(d\geq 1\) is declared by the evaluation: \(d=1\) gives scalar utility, while \(d>1\) retains several outcomes or costs without an implicit weighting. Equip both seed sets with declared sigma-algebras and \(\mathbb R^d\) with its Borel sigma-algebra. Products below carry the product sigma-algebra; finite or countable discrete spaces may use all subsets. A seed space alone does not specify its sampling law.
Definition. Task [ftip-001O]AGENTDRAFTED
Definition. Task [ftip-001O]AGENTDRAFTED
A task is a triple \[ \mathsf T=(\mathcal X_{\mathsf T},\mathcal O_{\mathsf T}, \operatorname {Adm}_{\mathsf T}), \] where \(\mathcal X_{\mathsf T}\) is an instance set, \(\mathcal O_{\mathsf T}\) is a candidate-outcome set, and \(\operatorname {Adm}_{\mathsf T}(x,o)\) is a declared well-formedness predicate for an instance-outcome pair.
Admissibility says that an outcome can be interpreted for the instance; it does not say that the outcome is correct, useful, or safe. Those judgments belong to the evaluation utility introduced later.
Definition. Task law [ftip-001Q]AGENTDRAFTED
Definition. Task law [ftip-001Q]AGENTDRAFTED
For the instance set in Definition [ftip-001O], a task law is a probability law \(\mu _{\mathsf T}\) on \(\mathcal X_{\mathsf T}\). An evaluation sample of size \(N\) is a declared joint law of instances \((X_1,\ldots ,X_N)\) whose marginals are \(\mu _{\mathsf T}\); independent sampling is a further assumption, not part of the term ``task law.''
In an episodic control problem this law includes the distribution of starting situations. In a fixed benchmark it may instead be the uniform law on a held-out finite set. Reweighting instances changes the task law even when the instance files are unchanged.
Remark. Response tasks and interactive tasks [ftip-001P]AGENTDRAFTED
Remark. Response tasks and interactive tasks [ftip-001P]AGENTDRAFTED
A task and a task law specify admissible instance--outcome pairs and how instances are sampled. Benchmark datasets usually present an input and expect an answer in a parseable format. Reinforcement-learning formulations instead name states, actions, and reward; see [sutton2018reinforcement, Chapter 3]. The admissibility predicate captures parseability, while the law records how instances are sampled. Neither choice already identifies parsing with success.
One-shot inference and an interactive environment can share the same task interface. Claims about an interaction's temporal structure additionally depend on the environment and the observations available at each decision.
Definition. Evaluation inference protocol [ftip-001R]AGENTDRAFTED
Definition. Evaluation inference protocol [ftip-001R]AGENTDRAFTED
Let \(M\) be an executable model artifact of the form in Definition [ftip-001K]. An evaluation inference protocol is a specified procedure \[ \mathsf I(M,x,b_{\mathrm {eval}};\xi )=(o,c) \in \mathcal O_{\mathsf T}\times \mathcal B_{\mathrm {eval}}, \] where \(x\in \mathcal X_{\mathsf T}\), \(b_{\mathrm {eval}}\in \mathcal B_{\mathrm {eval}}\), and \(\xi \in \Omega _I\) use the notation of Notation [ftip-001N]; \(o\) is a candidate outcome and \(c\in \mathcal B_{\mathrm {eval}}\) is the realized resource-use vector. A valid execution satisfies \(c\preceq b_{\mathrm {eval}}\) coordinatewise.
The protocol fixes prompt construction, decoding, sampling temperature, number of candidates, candidate selection, allowed tools, stopping, and any test-time search. None of these choices is determined by the checkpoint alone.
Remark. Decoding and test-time compute belong to evaluation [ftip-001S]AGENTDRAFTED
Remark. Decoding and test-time compute belong to evaluation [ftip-001S]AGENTDRAFTED
One next-token law supports many evaluation procedures. Greedy decoding, temperature sampling, majority voting, verifier-guided selection, and multi-round tool use can produce different outcome laws from the same checkpoint. The sampling and selection procedures in [shao2024deepseekmath, secs. 3--4] are concrete examples.
Accordingly, a comparison that changes \(b_{\mathrm {eval}}\) or \(\mathsf I\) does not estimate a training-only effect. A potential frontier therefore depends on evaluation-time compute as well as the trained model.
Definition. Evaluation utility [ftip-001T]AGENTDRAFTED
Definition. Evaluation utility [ftip-001T]AGENTDRAFTED
With the notation of Notation [ftip-001N], an evaluation utility is a declared measurable function \[ u_{\mathsf T}:\mathcal X_{\mathsf T}\times \mathcal O_{\mathsf T}\times \Omega _E\longrightarrow \mathbb R^d, \] where \(\Omega _E\) is the evaluator's measurable seed space. The evaluator applies it only to admissible pairs from Definition [ftip-001O]. A deterministic evaluator is the special case in which the value does not depend on \(\omega \in \Omega _E\).
Binary pass-fail evaluation takes \(d=1\) and values in \(\{0,1\}\). A cumulative return is another scalar case. Vector utility keeps qualities such as correctness, safety, latency, and tool cost distinct until a later rule declares how to compare them.
Whenever an expected utility vector is used, its composite evaluation random variable must be measurable and absolutely integrable in every coordinate under the declared joint law. Thus its expectation lies in \(\mathbb R^d\). Bounded measurable utility is a sufficient specialization; so is finite support for the complete evaluation random variable with finite values on that support. Merely taking a finite real value at each seed is insufficient for an unbounded evaluator. The scalar protocol comparison in Convention [ftip-005D] states its joint law explicitly.
Remark. Scalar returns and multiple evaluation quantities [ftip-006N]AGENTDRAFTED
Remark. Scalar returns and multiple evaluation quantities [ftip-006N]AGENTDRAFTED
Sutton and Barto define scalar episodic return in [sutton2018reinforcement, Section 3.3]. Benchmarks also use exact-match, test, latency, safety, and cost measurements. A proposed seeded vector utility keeps those coordinates separate, with evaluator randomness included in the declared law.
The vector is not a claim that its coordinates share a natural scale. Scalarization, Pareto order, and worst-group summaries are introduced only after the attainable evaluation set is defined.
Example. One policy under two evaluation inference budgets [ftip-001U]AGENTDRAFTED
Example. One policy under two evaluation inference budgets [ftip-001U]AGENTDRAFTED
One fixed policy can receive different measured success rates when the evaluation horizon changes.
Partition complete trajectories into those that finish within the short horizon, those requiring additional tokens, and failures. The short protocol counts only the first class; the longer protocol may count the first two. Thus the measured score depends on the declared horizon even though the policy is unchanged.
Making an evaluation horizon explicit follows finite-horizon policy evaluation in [sutton2018reinforcement, Chapter 3]. Only truncation is varied here. Larger budgets need not help once decoding rules, tool costs, or selection errors are allowed to change with the budget.
Remark. Public task data and evaluator-only information [ftip-001V]AGENTDRAFTED
Remark. Public task data and evaluator-only information [ftip-001V]AGENTDRAFTED
The inference protocol receives only the information designated as public. The public instance \(x\) may include a prompt, tools, and a response schema. Evaluator-only information may include a reference answer, hidden tests, a simulator state, or the evaluator seed \(\omega \). The protocol in Definition [ftip-001R] receives the former and not the latter.
If evaluator-only information influences training, decoding, or candidate selection, the experiment no longer measures performance under the declared information interface. A theorem that assumes an independent evaluator must name the sigma-field or finite data record from which the protocol is excluded.
Interactive environments and policies [ftip-001W]AGENTDRAFTED
Interactive environments and policies [ftip-001W]AGENTDRAFTED
Some tasks end with one generated response. Agentic tasks instead alternate between an acting system and an environment: the system calls a tool, receives an observation, and chooses what to do next. The following objects make that temporal and informational structure explicit before any reinforcement-learning objective is introduced.
Notation. State, observation, action, time, history, and stopping [ftip-001X]AGENTDRAFTED
Notation. State, observation, action, time, history, and stopping [ftip-001X]AGENTDRAFTED
Let \(\mathcal S,\mathcal O,\mathcal A\) be declared measurable spaces of environment states, public observations, and agent actions. Time is discrete, \(t\in \{0,1,\ldots ,T_{\max }\}\), where \(T_{\max }<\infty \) is a hard horizon. Random states, observations, and actions are \(S_t,O_t,A_t\); lowercase \(s_t,o_t,a_t\) denote realized values. The same convention makes \(h_t\) a realization of \(H_t\) and \(z\) a realization of \(Z\).
The public history available before action \(A_t\) is \(H_t\); the full environment trajectory is \(Z\); and the stopping time is \(\tau _{\mathrm {stop}}\in \{0,1,\ldots ,T_{\max }\}\). Probability kernels are written \(K(dy\mid x)\); on finite spaces this means the probability law \(K(y\mid x)\) and reduces to the notation of Notation [ftip-000A].
Definition. Initial-state law [ftip-001Y]AGENTDRAFTED
Definition. Initial-state law [ftip-001Y]AGENTDRAFTED
With the spaces in Notation [ftip-001X], an initial-state law \(\rho _0(ds_0,do_0)\) is a probability law on \(\mathcal S\times \mathcal O\). It jointly samples the hidden initial state \(S_0\) and the first public observation \(O_0\).
Allowing a joint law covers both a deterministic rendering \(O_0=\operatorname {obs}(S_0)\) and a noisy initial observation. A fixed task instance can be included as a coordinate of \(O_0\); its sampling law is then the task law of Definition [ftip-001Q].
Definition. Transition-observation kernel [ftip-001Z]AGENTDRAFTED
Definition. Transition-observation kernel [ftip-001Z]AGENTDRAFTED
A transition-observation kernel at time \(t\) is a probability kernel \[ K_t(ds_{t+1},do_{t+1}\mid s_t,a_t) \] from the current hidden state and action to the next hidden state and public observation. After \(A_t=a_t\), the environment draws \((S_{t+1},O_{t+1})\) from this kernel.
The factorization \(K_t(ds',do'\mid s,a)=P_t(ds'\mid s,a)\,Q_t(do'\mid s',a)\) for declared kernels \(P_t\) and \(Q_t\) recovers the usual separate state-transition and observation kernels when such a factorization is declared. The joint-kernel form does not assume it.
Remark. Deterministic tools and stochastic environments [ftip-0020]AGENTDRAFTED
Remark. Deterministic tools and stochastic environments [ftip-0020]AGENTDRAFTED
The kernel in Definition [ftip-001Z] describes both tools and broader environments. A deterministic tool has a measurable update map \(F_t(s,a)=(s',o')\) and the point-mass kernel concentrated at \(F_t(s,a)\). A stochastic environment permits several next state-observation pairs for the same input.
This distinction matters for replay. Re-executing a deterministic tool call under an unchanged state reproduces its observation, whereas a stored rollout from a stochastic environment is one sample from a conditional law. Any analysis that replaces one with the other needs a coupling or concentration assumption.
Definition. Public history [ftip-0021]AGENTDRAFTED
Definition. Public history [ftip-0021]AGENTDRAFTED
At time \(t\), the public history is the alternating sequence \[ H_t=(O_0,A_0,O_1,A_1,\ldots ,A_{t-1},O_t). \] Thus \(H_0=(O_0)\). It contains exactly the observations received and actions taken before the next action \(A_t\); it does not contain the hidden state \(S_t\) unless that state was itself revealed as an observation.
Remark. The information boundary of a history [ftip-0022]AGENTDRAFTED
Remark. The information boundary of a history [ftip-0022]AGENTDRAFTED
The history in Definition [ftip-0021] contains the agent's available information. The hidden state sequence \((S_0,\ldots ,S_t)\), future observations, evaluator-only tests from Remark [ftip-001V], and future random seeds are absent unless the environment has already exposed them through \(O_0,\ldots ,O_t\).
This boundary determines which policies are implementable. It also separates legitimate memory from leakage: a summary of earlier public observations may be stored in the history, while a hidden reference answer may not be supplied under the same declaration.
Definition. Non-anticipating policy [ftip-0023]AGENTDRAFTED
Definition. Non-anticipating policy [ftip-0023]AGENTDRAFTED
A non-anticipating policy is a family of probability kernels \[ \pi _t(da\mid H_t), \qquad t=0,1,\ldots ,T_{\max }-1, \] from public histories in Definition [ftip-0021] to the action space \(\mathcal A\). At time \(t\), the action may depend on \(H_t\) and fresh policy randomness, but not on a later observation or an unobserved state.
A decoder-only language model becomes such a policy only after an inference protocol serializes \(H_t\) into tokens, decodes tokens, and parses them as an action. The next-token law in Definition [ftip-000H] alone does not specify those maps.
Definition. Stopping rule [ftip-0024]AGENTDRAFTED
Definition. Stopping rule [ftip-0024]AGENTDRAFTED
A stopping rule is a random time \(\tau _{\mathrm {stop}}\in \{0,1,\ldots ,T_{\max }\}\) such that, for each \(t\), the decision whether \(\tau _{\mathrm {stop}}=t\) is determined by the public history \(H_t\) and any declared stopping randomness available by time \(t\). It cannot inspect future observations.
Stopping can be triggered by a terminal environment observation, an agent action, a resource limit, or the hard horizon. The trigger and the owner of the decision are part of the rule.
Definition. Stopped trajectory [ftip-0025]AGENTDRAFTED
Definition. Stopped trajectory [ftip-0025]AGENTDRAFTED
If \(\tau _{\mathrm {stop}}=n\), the stopped trajectory is \[ Z=(S_0,O_0,A_0,S_1,O_1,A_1,\ldots , A_{n-1},S_n,O_n). \] It contains the environment states as well as the public action-observation record. Its public projection is the history \(H_n\) of Definition [ftip-0021].
For \(n=0\), the trajectory is \((S_0,O_0)\) and contains no action. A terminal utility may depend on the full trajectory when evaluated inside the environment, even though the policy is restricted to its public projection.
Definition. Interactive realization of a task [ftip-006T]AGENTDRAFTED
Definition. Interactive realization of a task [ftip-006T]AGENTDRAFTED
For a task \(\mathsf T=(\mathcal X_{\mathsf T},\mathcal O_{\mathsf T}, \operatorname {Adm}_{\mathsf T})\) from Definition [ftip-001O], an interactive realization is
\[ \mathsf {Env}_{\mathsf T} =\left (\mathcal S_{\mathsf T},\mathcal O^{\rm obs}_{\mathsf T}, \mathcal A_{\mathsf T},T_{\max }, (\rho _0^x)_x,(K_t^x)_{x,t},\operatorname {out}_{\mathsf T}\right ). \]For each \(x\in \mathcal X_{\mathsf T}\), the law \(\rho _0^x\) is on \(\mathcal S_{\mathsf T}\times \mathcal O^{\rm obs}_{\mathsf T}\), and \(K_t^x\) maps a state and action to the next state-observation law for \(0\leq t<T_{\max }\). The outcome map sends a stopped trajectory \(Z\) to \(\operatorname {out}_{\mathsf T}(x,Z)\in \mathcal O_{\mathsf T}\) and satisfies \(\operatorname {Adm}_{\mathsf T}(x,\operatorname {out}_{\mathsf T}(x,Z))\). For one fixed realization, write its three spaces as the unadorned \(\mathcal S,\mathcal O,\mathcal A\) of Notation [ftip-001X].
The agent policy and stopping rule are not environment fields. They are combined with this realization only when an interaction law is formed.
Remark. How a task acquires interactive semantics [ftip-006U]AGENTDRAFTED
Remark. How a task acquires interactive semantics [ftip-006U]AGENTDRAFTED
Section 3.1 of [sutton2018reinforcement] specifies the agent--environment interaction. Section 2 of [kaelbling1998planning] separates hidden state from observation. We combine those ingredients with the task interface of Definition [ftip-001O] so each task instance selects an initial law and transition kernels.
The outcome-extraction map is an additional interface choice; neither cited source supplies it in this task-indexed form. This map connects a stopped interaction to the candidate outcome that the independent evaluator will score.
Example. A finite agent--environment interaction loop [ftip-0026]AGENTDRAFTED
Example. A finite agent--environment interaction loop [ftip-0026]AGENTDRAFTED
A deterministic three-action episode records each observation before the next policy decision and ends with an explicit terminal observation.
Let \(H_0=(\text {door locked})\). After action \(A_0=\text {take key}\), the environment returns \(O_1=\text {key held}\), so \(H_1=(H_0,A_0,O_1)\). Repeating the same update with unlock and door open, then choosing \(A_2=\text {enter}\), produces \(O_3=\text {terminal success}\) and \(H_3=(H_2,A_2,O_3)\). No later observation is available to an earlier action choice.
The alternating action--observation interface is the finite-history form of the agent setup in [kaelbling1998planning, Section 2]. The trace checks chronology and termination; uncertain state, partial observability, and language-valued actions lie beyond this deterministic instance.
Example. Token generation as a stopped environment interaction [ftip-0027]AGENTDRAFTED
Example. Token generation as a stopped environment interaction [ftip-0027]AGENTDRAFTED
A prefix tree represents token emission as a finite interaction stopped either by an end token or by a hard length cap.
Take vocabulary \(\{a,\mathtt {EOS}\}\). The terminal histories are an immediate end token, an end token after \(a\), and a length-capped history \(aa\). Their probabilities are products of the conditional token laws and sum to one. The last history terminates because the declared maximum length is reached, not because the policy emitted \(\mathtt {EOS}\).
The causal token product is given in [phuong2022formal, Section 3]. The finite representation distinguishes two stopping mechanisms. Token steps remain distinct from tool calls, and unbounded generation is outside the construction.
Remark. The induced law of a stopped interaction [ftip-0028]AGENTDRAFTED
Remark. The induced law of a stopped interaction [ftip-0028]AGENTDRAFTED
Sutton and Barto's agent--environment interface in [sutton2018reinforcement, sec. 3.1] supplies alternating states, actions, and rewards. Kaelbling et al. separate hidden state and public observation in [kaelbling1998planning, Section 2]. A stopped interaction is determined by its initial law, transition--observation kernel, policy, and public stopping rule.
The induced interaction law uses four independently declared objects: the initial law \(\rho _0\) in Definition [ftip-001Y], the environment kernels \(K_t\) in Definition [ftip-001Z], the policy \(\pi _t\) in Definition [ftip-0023], and the stopping rule in Definition [ftip-0024]. On finite spaces, the probability of a length-\(n\) trajectory before applying its stopping indicator factors as \[ \rho _0(s_0,o_0) \prod _{t=0}^{n-1} \pi _t(a_t\mid h_t) K_t(s_{t+1},o_{t+1}\mid s_t,a_t). \] The event \(\{\tau _{\mathrm {stop}}=n\}\) selects the stopped trajectories.
This factorization supports later expectations, likelihood ratios, and off-policy reuse. It also exposes an identifiability limit: an outcome distribution by itself generally does not reveal which of the initial law, environment, policy, or stopping rule changed.
Post-training, alignment, and feedback [ftip-00JA]AGENTDRAFTED
Post-training, alignment, and feedback [ftip-00JA]AGENTDRAFTED
Post-training procedures differ in the information they receive and the updates they permit. Demonstrations, preferences, rewards, verifiers, and environment interactions impose different conditions on the resulting policy.
The chapter moves from demonstrations and preferences to reward-based updates, then to training through tool interaction and replay. The agent-state analysis complements these parameter-changing procedures by examining the contexts, memories and computation an agent retains around its models.
Fine-tuning [ftip-006P]AGENTDRAFTED
Fine-tuning [ftip-006P]AGENTDRAFTED
Fine-tuning continues parameter optimization from a pretrained artifact. The term names a relation between an initial checkpoint, training records, an objective, and an update process. It does not by itself specify instruction data, preference feedback, or reinforcement learning.
Definition. Fine-tuning run [ftip-006Q]AGENTDRAFTED
Definition. Fine-tuning run [ftip-006Q]AGENTDRAFTED
Given the base artifact \(M_0=(\tau ,\delta ,\mathsf {cfg},\theta _K,\mathsf {num})\) from Definition [ftip-001K], a fine-tuning run declares training records, a finite update count \(J\geq 0\), a loss \(L_{\rm ft}\), gradient estimators \(g_j^{\rm ft}\), optimizer states \(s_j^{\rm ft}\), and update specifications \((U_j,\eta _j^{\rm ft})\). It starts from \(\theta ^{\rm ft}_0=\theta _K\).
For each \(j=0,\ldots ,J-1\), the update is
\[ (\theta ^{\rm ft}_{j+1},s^{\rm ft}_{j+1}) =U_j\left (\theta ^{\rm ft}_j,s^{\rm ft}_j, g_j^{\rm ft},\eta _j^{\rm ft}\right ). \]Its output artifact replaces \(\theta _K\) by the final \(\theta ^{\rm ft}_J\). Any change to the tokenizer, architecture configuration, numerical convention, or other artifact field must be stated separately. Fine-tuning is not identified with one loss or data type.
Definition. Supervised fine-tuning in InstructGPT [ouyang2022training, Section 3.5 and Appendix C.1] [ftip-006H]AGENTDRAFTED
Definition. Supervised fine-tuning in InstructGPT [ouyang2022training, Section 3.5 and Appendix C.1] [ftip-006H]AGENTDRAFTED
In the cited pipeline, supervised fine-tuning (SFT) starts from a pretrained GPT-3 checkpoint and updates it by supervised learning on labeler demonstrations. The resulting policy supplies the starting and reference policy for later stages.
Appendix C.1 reports optimization choices for that construction. It does not define a universal mask, weighting rule, or fine-tuning protocol.
Remark. Fine-tuning objectives and supervised instances [ftip-006R]AGENTDRAFTED
Remark. Fine-tuning objectives and supervised instances [ftip-006R]AGENTDRAFTED
Wei et al. train on instruction-expressed task mixtures in [wei2022finetuned, Section 2 and Figure 2]. Ouyang et al. fine-tune on labeler demonstrations in [ouyang2022training, Section 3.5 and Appendix C.1]. The proposed continued-optimization interface in Definition [ftip-006Q] includes these concrete supervised instances.
Neither cited source defines fine-tuning as one universal objective. A concrete run must state its records, loss and normalization, optimizer, stopping rule, and trainable parameters. Instruction tuning later specializes the records to instruction--response demonstrations.
Instruction tuning [ftip-0029]AGENTDRAFTED
Instruction tuning [ftip-0029]AGENTDRAFTED
Instruction tuning uses demonstrations to connect the continuation law of a pretrained language model with requests written as instructions. The objects in this section separate the mathematical training record, its provenance, the reported collection procedure, and the loss used to update the model.
Notation. Prompts, responses, demonstrations, and loss masks [ftip-002A]AGENTDRAFTED
Notation. Prompts, responses, demonstrations, and loss masks [ftip-002A]AGENTDRAFTED
Let \(\mathcal X_{\mathrm {pr}}\) be the prompt space. For each prompt \(x\in \mathcal X_{\mathrm {pr}}\), let \(\mathcal Y(x)\subseteq \mathcal V^*\) be the set of finite token responses permitted by the training format. We write \(y=(y_1,\ldots ,y_{|y|})\in \mathcal Y(x)\) and \(y_{<t}=(y_1,\ldots ,y_{t-1})\).
A demonstration is denoted \(z=(x,y,\omega )\), where \(\omega \) is its provenance record. A finite multiset of demonstrations is denoted \(D_{\mathrm {sft}}\). For each response position, a loss mask \(m_t(z)\in \{0,1\}\) records whether the token contributes to the supervised objective, and a nonnegative weight \(w_t(z)\) records its declared normalization. Prompt tokens are conditioning context and lie outside the response-position domains of \(m_t(z)\) and \(w_t(z)\).
Definition. Prompt serializer [ftip-006V]AGENTDRAFTED
Definition. Prompt serializer [ftip-006V]AGENTDRAFTED
Using the prompt space of Notation [ftip-002A], a prompt serializer is a declared map \[ s_{\mathrm {pr}}:\mathcal X_{\mathrm {pr}}\longrightarrow \mathcal V^*. \] For token strings \(u,v\in \mathcal V^*\), write \(u\mathbin {\Vert }v\) for their concatenation. A response token \(y_t\) is therefore predicted from the token prefix \(s_{\mathrm {pr}}(x)\mathbin {\Vert }y_{<t}\).
The serializer fixes system text, role markers, separators, and any other prompt-side control tokens. Changing it changes the conditional examples seen by the language model even when the abstract prompts and responses are unchanged.
Remark. Why instruction data require serialization [ftip-006W]AGENTDRAFTED
Remark. Why instruction data require serialization [ftip-006W]AGENTDRAFTED
The next-token law in Definition [ftip-000H] accepts token prefixes, whereas an instruction dataset may store structured prompts. The proposed serializer in Definition [ftip-006V] maps between those types. Ouyang et al. describe SFT on labeler demonstrations in [ouyang2022training, Section 3.5 and Appendix C.1]; their training account supplies a concrete pipeline rather than a universal serializer.
A reproducible objective must retain the serializer revision with the tokenizer and loss mask. Otherwise two runs can share an abstract dataset name while optimizing different token sequences.
Definition. Instruction tuning [wei2022finetuned, Section 2 and Figure 2] [ftip-002B]AGENTDRAFTED
Definition. Instruction tuning [wei2022finetuned, Section 2 and Figure 2] [ftip-002B]AGENTDRAFTED
Instruction tuning fine-tunes a pretrained language model on a mixture of tasks whose examples are expressed through natural-language instructions and corresponding target outputs. The task description and any input are placed in the prompt; the target output supplies the continuation to be learned.
The construction changes the model parameters by supervised learning. It does not require a learned reward model, preference comparisons, or interaction with an environment.
Definition. Demonstration record [ftip-002C]AGENTDRAFTED
Definition. Demonstration record [ftip-002C]AGENTDRAFTED
Using the notation of Notation [ftip-002A], a demonstration record is a triple
\[ z=(x,y,\omega ), \qquad x\in \mathcal X_{\mathrm {pr}},\quad y\in \mathcal Y(x), \]where \(\omega \) identifies the declared producer of \(y\), the collection or generation procedure, and any selection rule applied before the record entered \(D_{\mathrm {sft}}\). The response is a training target; its presence in the data does not assert that it is uniquely correct or preferred to every alternative.
Remark. Demonstration and teacher provenance [ftip-002D]AGENTDRAFTED
Remark. Demonstration and teacher provenance [ftip-002D]AGENTDRAFTED
The provenance field \(\omega \) distinguishes a demonstration from the process that supplied it. Ouyang et al. collect labeler-written demonstrations in [ouyang2022training, §§3.2, 3.4]. Wei et al. permit a broader task mixture in [wei2022finetuned, §2; Fig. 2].
Human writers, stronger teacher models, filtered self-generations, and programmatically produced targets give different information to the learner. Claims about sample efficiency or capability acquisition must therefore state which producer and selection rule were available.
Definition. Labeler demonstration collection [ouyang2022training, Sections 3.2 and 3.4] [ftip-002E]AGENTDRAFTED
Definition. Labeler demonstration collection [ouyang2022training, Sections 3.2 and 3.4] [ftip-002E]AGENTDRAFTED
In the InstructGPT data-collection procedure, a labeler receives a prompt and writes a desired response. The resulting prompt--response pair enters the demonstration data used by the supervised fine-tuning stage. Prompts come from the declared API and labeler-written sources, and the paper records filtering and labeler-selection procedures.
This construction specifies a human demonstration channel. It is distinct from the later comparison channel, in which a labeler ranks model-generated responses rather than writing the target response.
Definition. Supervised fine-tuning objective [ftip-002F]AGENTDRAFTED
Definition. Supervised fine-tuning objective [ftip-002F]AGENTDRAFTED
For the language-model policy \(\pi _\theta \) and the notation of Notation [ftip-002A], a masked supervised fine-tuning (SFT) objective has the form
\[ L_{\mathrm {sft}}(\theta ) =-\sum _{z=(x,y,\omega )\in D_{\mathrm {sft}}} \sum _{t=1}^{|y|}w_t(z)m_t(z) \log \pi _\theta \left (y_t\mid s_{\mathrm {pr}}(x)\mathbin {\Vert }y_{<t}\right ), \]where the nonnegative weights satisfy \(\sum _{z\in D_{\mathrm {sft}}}\sum _{t=1}^{|y|}w_t(z)m_t(z)=1\). The response index \(t\) does not range over serialized prompt tokens. Minimizing this objective increases conditional likelihood on the selected target tokens. The weights and mask are local conventions and must be declared for each implementation.
Convention. Response-token normalization [ftip-002G]AGENTDRAFTED
Convention. Response-token normalization [ftip-002G]AGENTDRAFTED
For a finite demonstration multiset, define the number of selected response tokens by
\[ N_{\mathrm {resp}} =\sum _{z=(x,y,\omega )\in D_{\mathrm {sft}}} \sum _{t=1}^{|y|}m_t(z). \]When \(N_{\mathrm {resp}}>0\), response-token normalization sets \(w_t(z)=N_{\mathrm {resp}}^{-1}\) at every selected position. Each selected token then has equal weight in \(L_{\mathrm {sft}}\). Equal weighting of records or prompts is a different convention because response lengths vary.
The training account alone does not determine this normalization. Any comparison of losses or gradients must retain the mask and normalization that produced them.
Example. Response-only supervision on one instruction record [ftip-002H]AGENTDRAFTED
Example. Response-only supervision on one instruction record [ftip-002H]AGENTDRAFTED
Two instruction positions provide conditioning context but lie outside the response-loss index set. The loss is taken on the two generated tokens.

Declare \(\pi (r_1\mid u_1,u_2)=1/2\) and \(\pi (r_2\mid u_1,u_2,r_1)=1/4\). The instruction tokens are not indexed by the response mask. With mask one on each displayed response token, the sum and mean are \[ L_{\rm sum}=-\log \tfrac 12-\log \tfrac 14=\log 8, \qquad L_{\rm mean}=\tfrac 12\log 8\approx 1.040. \]
The supervised objective in Definition [ftip-002F] and the causal factorization in Definition [ftip-000I] specialize to the displayed token strip. Its mask is a local choice on response positions; other instruction-tuning implementations may supervise a different subset of response tokens or declare a larger loss domain explicitly.
Remark. What instruction tuning changes and leaves open [ftip-002I]AGENTDRAFTED
Remark. What instruction tuning changes and leaves open [ftip-002I]AGENTDRAFTED
Instruction tuning changes conditional likelihood under a declared demonstration distribution. It can teach response format, task interpretation, and behavior represented by the targets, but the training loss alone does not identify which of those effects caused an independent evaluation gain.
Ouyang et al. report supervised fine-tuning and its optimization settings in [ouyang2022training, Section 3.5 and Appendix C.1]. They do not define the exact mask and weighting convention displayed in Definition [ftip-002F]; those choices remain part of the declared objective.
The stage also leaves several questions open. A demonstration does not compare its target with alternatives, a teacher may transmit errors or hidden information, and low loss on the collected prompts need not imply transfer to a new task law. Preference acquisition introduces a different observation: which response a judge selected from a displayed pair.
Preference acquisition and reward modeling [ftip-002J]AGENTDRAFTED
Preference acquisition and reward modeling [ftip-002J]AGENTDRAFTED
Preference data records a judge's choice between displayed alternatives. Reward modeling adds a statistical representation of those choices. This section keeps the acquisition procedure, observation law, score model, and validation law separate so that a scalar predictor is not mistaken for the preferences it was fitted to represent.
Notation. Comparison queries, judges, and response pairs [ftip-002K]AGENTDRAFTED
Notation. Comparison queries, judges, and response pairs [ftip-002K]AGENTDRAFTED
Use the prompt and response spaces from Notation [ftip-002A]. A comparison query is a displayed triple \(c=(x,y^0,y^1)\) with \(y^0,y^1\in \mathcal Y(x)\). Let \(\mathcal J\) be the declared judge population, and let \(j\in \mathcal J\) identify the human, model, or rule that returns a comparison label \(b_{\mathrm {pref}}\in \{0,1\}\).
When \(b_{\mathrm {pref}}=1\), write \(y^+=y^1\) and \(y^-=y^0\); when \(b_{\mathrm {pref}}=0\), reverse those names. Thus \(y^+\) means selected in this observation, not objectively or uniquely best. The acquisition mechanism may also record a tie, abstention, or invalid comparison, but those outcomes must use an enlarged label space rather than being silently forced into \(\{0,1\}\).
Definition. Pairwise comparison observation [ftip-002L]AGENTDRAFTED
Definition. Pairwise comparison observation [ftip-002L]AGENTDRAFTED
Restrict attention to a comparison for which the judge selects one displayed alternative rather than reporting indifference or incomparability. For a query \(c=(x,y^0,y^1)\) and a judge \(j\), a pairwise comparison observation is the displayed pair together with the judge's selected alternative. In winner--loser notation it is recorded as
\[ o=(x,y^+,y^-,j). \]The observation reports a choice made under the declared presentation and query procedure. It does not by itself provide a numerical reward, a complete ranking of responses, or a judgment about alternatives that were not shown.
Definition. Preference query selection [christiano2017deep, Section 2.2.4] [ftip-002M]AGENTDRAFTED
Definition. Preference query selection [christiano2017deep, Section 2.2.4] [ftip-002M]AGENTDRAFTED
Preference learning may choose which trajectory segments or responses to show to a judge rather than sampling every pair uniformly. The query-selection procedure assigns candidate comparisons a priority derived from the current reward-model ensemble and requests labels for selected pairs.
Because selection depends on the current model and candidate pool, the resulting comparison data reflect an acquisition policy. Active selection can concentrate labels on uncertain pairs, but it does not make the collected comparisons representative of an undeclared target population.
Remark. Preference acquisition and judge provenance [ftip-002N]AGENTDRAFTED
Remark. Preference acquisition and judge provenance [ftip-002N]AGENTDRAFTED
A preference observation depends on the query presented and the judge who evaluates it. Concrete elicitation procedures include [christiano2017deep, Sections 2.2.2 and 2.2.4] and the language-model comparison pipeline of [ouyang2022training, Sections 3.2 and 3.4].
The response generator, pair-selection rule, presentation order, judge population, and aggregation rule can each change the observed law. A later sample-complexity or population claim must condition on those choices rather than treating comparison labels as an unqualified source of ground truth.
Definition. Preference data law [ftip-002O]AGENTDRAFTED
Definition. Preference data law [ftip-002O]AGENTDRAFTED
A preference data law \(\mathcal D_{\mathrm {pref}}\) is a probability law on pairwise comparison observations \(o=(x,y^+,y^-,j)\) from Definition [ftip-002L]. It includes the randomness of prompt selection, response generation, pair selection, judge selection, and the judge's reported label.
A finite training multiset \(D_{\mathrm {pref}}=(o_1,\ldots ,o_N)\) is sampled or adaptively collected under that law and its acquisition history. When queries are adaptive, the records need not be independent or identically distributed.
Definition. Scalar reward-model score [ouyang2022training, Section 3.5 and Appendix C.2] [ftip-002P]AGENTDRAFTED
Definition. Scalar reward-model score [ouyang2022training, Section 3.5 and Appendix C.2] [ftip-002P]AGENTDRAFTED
A scalar reward model is a parameterized function
\[ r_\phi :\{(x,y):x\in \mathcal X_{\mathrm {pr}},\ y\in \mathcal Y(x)\} \longrightarrow \mathbb R, \]whose score is fitted from comparison observations. The score orders or weights responses for a specified training procedure; it is not automatically the independent utility of the response. Ouyang et al. initialize the model from the supervised policy and replace its language-model head with a scalar output for this stage.
Definition. Bradley--Terry comparison law [bradley1952rank, Page 325, equation (1)] [ftip-002Q]AGENTDRAFTED
Definition. Bradley--Terry comparison law [bradley1952rank, Page 325, equation (1)] [ftip-002Q]AGENTDRAFTED
Given scalar scores for two alternatives, the Bradley--Terry comparison law assigns the probability
\[ \Pr _\phi (y^+\succ y^-\mid x) =\frac {\exp r_\phi (x,y^+)} {\exp r_\phi (x,y^+)+\exp r_\phi (x,y^-)} =\sigma \left (r_\phi (x,y^+)-r_\phi (x,y^-)\right ), \]where \(\sigma (a)=(1+\exp (-a))^{-1}\). Conditioning the scores on a language-model prompt is the contextual specialization used in modern reward modeling; see also [rafailov2023direct, Section 3, equation (1)].
Definition. Pairwise reward-model loss [ouyang2022training, Section 3.5, equation (1), and Appendix C.2] [ftip-002R]AGENTDRAFTED
Definition. Pairwise reward-model loss [ouyang2022training, Section 3.5, equation (1), and Appendix C.2] [ftip-002R]AGENTDRAFTED
For comparison observations sampled from \(\mathcal D_{\mathrm {pref}}\), the pairwise reward-model loss is
\[ L_{\mathrm {rm}}(\phi ) =\mathbb E_{(x,y^+,y^-,j)\sim \mathcal D_{\mathrm {pref}}} \left [-\log \sigma \left ( r_\phi (x,y^+)-r_\phi (x,y^-) \right )\right ]. \]The empirical objective replaces the expectation by a declared weighting of the collected comparisons. It fits score differences under the Bradley--Terry law of Definition [ftip-002Q]; it does not observe an absolute reward target for either response.
Remark. Representability, non-identifiability, and heterogeneous preferences [ftip-002S]AGENTDRAFTED
Remark. Representability, non-identifiability, and heterogeneous preferences [ftip-002S]AGENTDRAFTED
Fitting a Bradley--Terry predictor is an assumption about representation, not a consequence of observing comparisons. Cyclic choices, context effects, and mixtures of judges can fail to agree with one shared scalar ordering.
Even within the model, scores are not identified absolutely: replacing \(r_\phi (x,y)\) by \(r_\phi (x,y)+c(x)\) leaves every pairwise probability and the loss unchanged. Ouyang et al. give one normalization in [ouyang2022training, §3.5; App. C.2]. Other uses must state their own normalization, judge population, and validation law.
Example. A Bradley--Terry comparison calculation [ftip-002T]AGENTDRAFTED
Example. A Bradley--Terry comparison calculation [ftip-002T]AGENTDRAFTED
A declared difference between two reward scores maps to one Bradley--Terry preference probability.
Under the Bradley--Terry link, \[ \Pr (y^+\succ y^-\mid x) =\frac {\exp r(y^+)}{\exp r(y^+)+\exp r(y^-)} =\sigma (2-0.5) =\sigma (1.5)\approx 0.8176. \] Reversing the pair gives probability \(1-0.8176=0.1824\).
The fixed scores instantiate Definition [ftip-002Q] and determine the displayed probability. Whether one scalar reward can represent every judge is a separate modeling question.
Definition. Reward-model validation law [ftip-002U]AGENTDRAFTED
Definition. Reward-model validation law [ftip-002U]AGENTDRAFTED
A reward-model validation law \(\mathcal D_{\mathrm {rm}}^{\mathrm {val}}\) is a held-out law on comparison observations used to evaluate the fitted score model rather than to update \(\phi \). A declared validation statistic may be Bradley--Terry log loss or the probability that \(r_\phi (x,y^+)>r_\phi (x,y^-)\).
The validation population and acquisition procedure are part of the quantity. Accuracy on comparisons drawn from the same collection process does not establish calibration under a new judge population or agreement with an independent task-success criterion.
Remark. Reward-model validation depends on its population [ftip-006O]AGENTDRAFTED
Remark. Reward-model validation depends on its population [ftip-006O]AGENTDRAFTED
Ouyang et al. hold out comparison data and report reward-model validation accuracy and loss in [ouyang2022training, Section 3.5 and Appendix C.2]. Representing the validation population by a probability law makes the estimand depend explicitly on the judge population and acquisition procedure.
This law belongs to reward-model validation. It is not the independent task evaluation used later to compare post-training protocols.
Example. Cyclic preferences that no scalar ordering represents [ftip-002V]AGENTDRAFTED
Example. Cyclic preferences that no scalar ordering represents [ftip-002V]AGENTDRAFTED
Three strict comparisons arranged in a directed cycle obstruct representation by a single scalar ordering.
Declare \(A\succ B\), \(B\succ C\), and \(C\succ A\). If a scalar \(r\) represented all three comparisons by strict inequalities, then \[ r(A)>r(B)>r(C)>r(A), \] which implies \(r(A)>r(A)\), a contradiction. Thus no real-valued score can represent this cycle by ordinary greater-than.
Scalar pairwise reward modeling is used in [christiano2017deep, Section 2]; the finite cycle marks one assumption needed for that reduction. No empirical cycle is attributed to a particular dataset or population, and the obstruction concerns scalar orderings rather than all preference models.
Reinforcement-learning foundations [ftip-002W]AGENTDRAFTED
Reinforcement-learning foundations [ftip-002W]AGENTDRAFTED
Reinforcement learning updates a policy from rewards attached to sampled behavior. Before considering a particular alignment method, this section fixes the response-level episode, return, value, advantage, policy roles, and likelihood ratios used by policy-gradient objectives.
Notation. Reward, return, policy roles, value, advantage, and likelihood ratios [ftip-002X]AGENTDRAFTED
Notation. Reward, return, policy roles, value, advantage, and likelihood ratios [ftip-002X]AGENTDRAFTED
The ratio and policy-objective formulas in this section specialize the measurable policy interface of Definition [ftip-0023] to a declared finite or countable discrete action space. Thus \(\pi (a\mid h)\) denotes probability mass, not an unspecified density. Whenever \(\log \pi _\theta (A_t\mid H_t)\) is displayed, its sampled mass is assumed positive.
For decision times \(t=0,\ldots ,N-1\), write \(\mathsf H_t:=H_t\) for the public history defined in Definition [ftip-0021], \(A_t\) for its action, and \(R_{t+1}\in \mathbb R\) for the next reward. Let \(\gamma \in [0,1]\) be the discount factor and \(G_t\) the return from time \(t\).
Write \(\pi _b\) for the behavior policy that produced a stored action, \(\pi _\theta \) for the current trainable policy, and \(\pi _{\mathrm {ref}}\) for a fixed reference policy. Their value, action-value, and advantage functions are denoted \(V^\pi \), \(Q^\pi \), and \(A^\pi \); an estimated advantage is \(\widehat A_t\). The current-to-behavior likelihood ratio is denoted \(\rho _t(\theta )\).
In a response-level episode, \(\pi _\theta (y\mid x)\) abbreviates the completed-continuation probability \(P_\theta (y\mid s_{\mathrm {pr}}(x))\) of the response-task interface, using the declared prompt serializer; the same convention applies to \(\pi _b\) and \(\pi _{\mathrm {ref}}\). In an interactive episode these symbols instead denote the action laws on public histories defined in Definition [ftip-0023].
Definition. Response-level episode [ouyang2022training, Section 3.5] [ftip-002Y]AGENTDRAFTED
Definition. Response-level episode [ouyang2022training, Section 3.5] [ftip-002Y]AGENTDRAFTED
In the response-level specialization used for language-model RLHF, a prompt \(x\) is the initial context, a complete response \(y\sim \pi _\theta (\mathord \cdot \mid x)\) is the sampled action, and a scalar score supplies the terminal reward. The episode terminates after that response.
This contextual-bandit view is sufficient for sequence-level reward-model training. Token generation may still be exposed as multiple policy decisions when an optimizer assigns token-level likelihood ratios or advantages. A later agentic setting also permits environment observations and tool actions between model responses.
Definition. Scalar reward [sutton2018reinforcement, Section 3.2] [ftip-002Z]AGENTDRAFTED
Definition. Scalar reward [sutton2018reinforcement, Section 3.2] [ftip-002Z]AGENTDRAFTED
A scalar reward \(R_{t+1}\in \mathbb R\) is the numerical signal received after action \(A_t\) and before the next decision. Its probabilistic law may depend on the current history, action, and environment transition.
Reward specifies the training objective of the reinforcement-learning problem. It need not equal an independent evaluator's utility, and a terminal reward need not identify which earlier action caused the outcome.
Definition. Return [sutton2018reinforcement, Section 3.3] [ftip-0030]AGENTDRAFTED
Definition. Return [sutton2018reinforcement, Section 3.3] [ftip-0030]AGENTDRAFTED
For an episode ending at time \(N\), the return from decision time \(t\) is
\[ G_t=\sum _{k=t}^{N-1}\gamma ^{k-t}R_{k+1}. \]When all intermediate rewards vanish, every return is determined by the terminal reward, up to discounting. Return is a random variable under the policy and environment law; its expectation defines value.
Definition. Value function [sutton2018reinforcement, Section 3.5] [ftip-0031]AGENTDRAFTED
Definition. Value function [sutton2018reinforcement, Section 3.5] [ftip-0031]AGENTDRAFTED
For a policy \(\pi \), the value function and action-value function are
\[ V^\pi (h)=\mathbb E_\pi [G_t\mid \mathsf H_t=h], \qquad Q^\pi (h,a)=\mathbb E_\pi [G_t\mid \mathsf H_t=h,A_t=a], \]whenever the conditional expectations exist. Both quantities depend on the reward, transition law, horizon, discount, and the policy followed after the conditioned decision.
Definition. Advantage function [schulman2016gae, Section 2] [ftip-0032]AGENTDRAFTED
Definition. Advantage function [schulman2016gae, Section 2] [ftip-0032]AGENTDRAFTED
For a policy \(\pi \), its advantage function is
\[ A^\pi (h,a)=Q^\pi (h,a)-V^\pi (h). \]The advantage compares an action with the policy's average continuation value at the same information state. Policy-gradient implementations replace it by an estimator \(\widehat A_t\); the estimator and the mathematical advantage are not interchangeable without assumptions on bias and variance.
Remark. Baselines and estimated credit [schulman2016gae, Sections 2--3] [ftip-0033]AGENTDRAFTED
Remark. Baselines and estimated credit [schulman2016gae, Sections 2--3] [ftip-0033]AGENTDRAFTED
Subtracting a baseline that does not depend on the sampled action can reduce the variance of a policy-gradient estimator without changing its expected gradient under the source conditions. A learned value function, a group mean, and a leave-one-out mean are different baselines and have different finite-data dependencies.
An estimated advantage may use sampled returns, bootstrapped values, or a mixture of both. Its error enters the update even when the likelihood-ratio calculation is exact.
Definition. Behavior, current, and reference policies [schulman2017proximal, Sections 2--3] [ftip-0034]AGENTDRAFTED
Definition. Behavior, current, and reference policies [schulman2017proximal, Sections 2--3] [ftip-0034]AGENTDRAFTED
The behavior policy \(\pi _b\) is the policy that generated a sampled action. The current policy \(\pi _\theta \) is the policy whose parameters are being optimized. Proximal policy optimization (PPO) collects a batch under an old policy and then compares candidate current policies with that data.
A reference policy \(\pi _{\mathrm {ref}}\) is instead held fixed to define a regularizer or preference objective; see [rafailov2023direct, Section 3, equation (3)]. It need not equal the behavior policy that generated a later rollout.
Definition. Likelihood ratio [schulman2017proximal, Section 2, equation (3)] [ftip-0035]AGENTDRAFTED
Definition. Likelihood ratio [schulman2017proximal, Section 2, equation (3)] [ftip-0035]AGENTDRAFTED
For an action \(A_t\) sampled from \(\pi _b\) at information state \(\mathsf H_t\), the current-to-behavior likelihood ratio is
\[ \rho _t(\theta ) =\frac {\pi _\theta (A_t\mid \mathsf H_t)}{\pi _b(A_t\mid \mathsf H_t)}. \]The ratio is defined on sampled actions for which \(\pi _b(A_t\mid \mathsf H_t)>0\). A bounded or clipped sampled ratio does not by itself control policy probabilities at unvisited histories.
Convention. Empirical sample average [ftip-006Z]AGENTDRAFTED
Convention. Empirical sample average [ftip-006Z]AGENTDRAFTED
For a nonempty finite index set \(I\) and real values \((Z_i)_{i\in I}\in \mathbb R^I\), write \[ \widehat {\mathbb E}_{i\in I}[Z_i] =\frac 1{|I|}\sum _{i\in I}Z_i. \] When the subscript is only \(t\), the index set is the declared collection of sampled decision times in the current batch.
PPO uses empirical expectation notation for its sampled surrogates; see Section 2, equations (1)--(2) of [schulman2017proximal]. The batch and its weighting must still be declared; the hat does not assert unbiasedness.
Definition. Policy-gradient surrogate [schulman2017proximal, Section 2, equations (1)--(2)] [ftip-0036]AGENTDRAFTED
Definition. Policy-gradient surrogate [schulman2017proximal, Section 2, equations (1)--(2)] [ftip-0036]AGENTDRAFTED
For samples collected under the declared behavior law and estimated advantages \(\widehat A_t\), the empirical policy-gradient surrogate is the following sample average:
\[ L^{\mathrm {PG}}(\theta ) =\widehat {\mathbb E}_t \left [\log \pi _\theta (A_t\mid \mathsf H_t)\,\widehat A_t\right ]. \]Its gradient is the familiar score-function estimator. The sampled states, actions, and advantage estimator are held fixed while differentiating this surrogate; changing the data-collection law defines a different estimator.
Example. Return and advantage on a three-step episode [ftip-0037]AGENTDRAFTED
Example. Return and advantage on a three-step episode [ftip-0037]AGENTDRAFTED
On a three-step episode, a discounted return and a baseline-relative advantage can be computed separately.
Take discount \(\gamma =1/2\). The return attached to the first action is \[ G_0=r_1+\gamma r_2+\gamma ^2 r_3 =0+\tfrac 12+\tfrac 14\cdot 2=1. \] If the declared baseline is \(V(s_0)=0.4\), then the corresponding advantage estimate is \(\widehat A_0=G_0-V(s_0)=0.6\).
The calculation instantiates the return and advantage in Definition [ftip-0030] and Definition [ftip-0032]. It illustrates one baseline choice. Low variance and correct attribution of terminal reward to an internal decision require additional assumptions or evidence.
Remark. Delayed credit and estimator scope [ftip-0038]AGENTDRAFTED
Remark. Delayed credit and estimator scope [ftip-0038]AGENTDRAFTED
A terminal response score can be copied into returns for many token decisions, but that bookkeeping does not reveal which token caused the score.
Monte Carlo returns, learned values, generalized advantage estimation, and group-relative normalization make different bias, variance, and dependence choices. Any theorem about an update must name the estimator actually used, the behavior policy that supplied its samples, and the horizon over which its credit signal is propagated.
Alignment training [ftip-006S]AGENTDRAFTED
Alignment training [ftip-006S]AGENTDRAFTED
Alignment training describes a declared role for a parameter-changing procedure: it is intended to alter behavior relative to a stated criterion. The criterion and the evidence used during training must be named before the claim can be evaluated.
Definition. Alignment-training claim [ftip-006I]AGENTDRAFTED
Definition. Alignment-training claim [ftip-006I]AGENTDRAFTED
An alignment-training claim is a capability claim \((M_0,A,E_{\rm align},b)\) in the sense of Convention [ftip-0003]. The procedure \(A\) changes model parameters and declares its training observations, loss or reward, and update rule. The independently fixed criterion \(E_{\rm align}\) states the behavior relative to which the word ``alignment'' is used.
Calling a procedure alignment training does not assert that its criterion is complete or that optimizing its training signal improves an independent evaluation.
Remark. Alignment criteria across different training routes [ftip-006J]AGENTDRAFTED
Remark. Alignment criteria across different training routes [ftip-006J]AGENTDRAFTED
Ouyang et al. combine demonstrations, comparison-trained rewards, and PPO in [ouyang2022training, Sections 3.1--3.5]. Direct Preference Optimization replaces the learned-reward PPO stage with a preference loss in [rafailov2023direct, Section 4]. The broader alignment-training description is a proposed way to compare such routes; it does not identify their observations or objectives with one another.
The declared behavioral criterion is part of the claim, while the independent evaluation remains a separate object. Their agreement is an empirical or theoretical claim, not a consequence of the word alignment.
Reinforcement learning from human feedback and proximal policy optimization [ftip-0039]AGENTDRAFTED
Reinforcement learning from human feedback and proximal policy optimization [ftip-0039]AGENTDRAFTED
RLHF, short for reinforcement learning from human feedback, names a family of alignment-training pipelines. One influential pipeline fits a supervised policy, learns a reward model from comparisons, and then optimizes the policy against that reward while limiting movement from a reference policy. This section separates those pipeline choices from proximal policy optimization (PPO), the optimization method used in its final stage.
Definition. Language-model RLHF pipeline [ouyang2022training, Section 3.1, Figure 2, and Section 3.5] [ftip-003A]AGENTDRAFTED
Definition. Language-model RLHF pipeline [ouyang2022training, Section 3.1, Figure 2, and Section 3.5] [ftip-003A]AGENTDRAFTED
The InstructGPT pipeline first performs supervised fine-tuning on labeler demonstrations. It then samples response pairs, collects labeler rankings, and fits a scalar reward model. Finally, it samples responses from the trainable policy and applies PPO using the reward-model score together with a penalty relative to the supervised policy.
The three stages consume different records and optimize different losses. Calling their composition RLHF does not make supervised targets, pairwise preferences, learned rewards, and policy-gradient samples the same kind of feedback.
Remark. Reward modeling, alignment criteria, and policy optimization [ftip-003B]AGENTDRAFTED
Remark. Reward modeling, alignment criteria, and policy optimization [ftip-003B]AGENTDRAFTED
The RLHF pipeline makes three logically separate choices. The comparison data specify which judgments were observed; the reward model specifies how those observations are represented and generalized; the policy optimizer specifies how sampled actions change the model.
An alignment criterion lies outside this chain unless it is identified with the training reward by assumption. A reward model can predict its held-out comparisons while failing under policy-induced distribution shift, and PPO can increase the learned reward while independent utility stays fixed or falls.
Definition. Kullback--Leibler divergence [ftip-006X]AGENTDRAFTED
Definition. Kullback--Leibler divergence [ftip-006X]AGENTDRAFTED
For probability mass functions \(p\) and \(q\) on a finite or countable set \(\mathcal Y\), the Kullback--Leibler divergence of \(p\) relative to \(q\) is \[ D_{\mathrm {KL}}(p\Vert q) =\sum _{y\in \mathcal Y}p(y)\log \frac {p(y)}{q(y)}. \] We use \(0\log (0/q)=0\). If \(p(y)>0\) and \(q(y)=0\) for some \(y\), the value is \(+\infty \). On a countable set, the negative part of the displayed series is finite; a divergent positive part gives the value \(+\infty \). Since \(\mathcal V^*\) is countable, the definition applies to the response laws of Notation [ftip-002A].
The order of the arguments matters. In particular, finiteness of the displayed forward divergence requires \(p\) to be absolutely continuous with respect to \(q\).
Remark. How the divergence enters alignment objectives [ftip-006Y]AGENTDRAFTED
Remark. How the divergence enters alignment objectives [ftip-006Y]AGENTDRAFTED
The KL-regularized reward objective appears as equation (3) in Section 3 of [rafailov2023direct]. Behavior-policy ratios, clipped ratios, and KL penalties enter alignment objectives for different purposes.
A coefficient multiplying \(D_{\mathrm {KL}}\) declares an optimization tradeoff. It is neither a guarantee that every sampled ratio is small nor an independent evaluation of the resulting policy.
Definition. KL-constrained RLHF objective [rafailov2023direct, Section 3, equation (3)] [ftip-003C]AGENTDRAFTED
Definition. KL-constrained RLHF objective [rafailov2023direct, Section 3, equation (3)] [ftip-003C]AGENTDRAFTED
Let \(\mu \) be a prompt law, \(r(x,y)\) a scalar reward, and \(\pi _{\mathrm {ref}}\) a fixed reference policy. For \(\beta >0\), the KL-regularized RLHF objective, using forward KL, is
\[ \max _{\pi } \mathbb E_{x\sim \mu ,\,y\sim \pi (\cdot \mid x)}[r(x,y)] -\beta \, \mathbb E_{x\sim \mu } \left [D_{\mathrm {KL}}\left ( \pi (\cdot \mid x)\Vert \pi _{\mathrm {ref}}(\cdot \mid x) \right )\right ]. \]The prompt law, reward, reference policy, and coefficient are part of the objective. The forward KL requires the optimized policy to be absolutely continuous with respect to the reference wherever the objective is finite.
Definition. KL-shaped PPO reward [ouyang2022training, Section 3.5, equation (2)] [ftip-003D]AGENTDRAFTED
Definition. KL-shaped PPO reward [ouyang2022training, Section 3.5, equation (2)] [ftip-003D]AGENTDRAFTED
For a prompt \(x\), sampled response \(y\), learned reward score \(r_\phi (x,y)\), and fixed reference policy \(\pi _{\mathrm {ref}}\), the sequence-level KL-shaped reward is
\[ R_{\mathrm {shape}}(x,y;\theta ) =r_\phi (x,y) -\beta \log \frac {\pi _\theta (y\mid x)} {\pi _{\mathrm {ref}}(y\mid x)}. \]Autoregressive factorization writes the logarithmic term as a sum of token-level log ratios. Ouyang et al. also mix a pretraining-gradient term into their reported PPO objective; that auxiliary term is separate from the shaped reward displayed here.
Definition. Generalized advantage estimator [schulman2016gae, Section 3, equations (10) and (16)] [ftip-003E]AGENTDRAFTED
Definition. Generalized advantage estimator [schulman2016gae, Section 3, equations (10) and (16)] [ftip-003E]AGENTDRAFTED
Given an approximate value function \(V\), with \(V(\mathsf H_N)=0\) at a terminal information state, define the temporal-difference residual
\[ \delta _t^V=R_{t+1}+\gamma V(\mathsf H_{t+1})-V(\mathsf H_t). \]For \(\lambda \in [0,1]\), the finite-episode generalized advantage estimator is
\[ \widehat A_t^{\mathrm {GAE}(\gamma ,\lambda )} =\sum _{l=0}^{N-t-1}(\gamma \lambda )^l\delta _{t+l}^V. \]The parameters \(\gamma \) and \(\lambda \) trade temporal reach against the variance and approximation error induced by bootstrapping. The estimator also depends on the fitted value function.
Definition. PPO clipped surrogate [schulman2017proximal, Section 3, equation (7)] [ftip-003F]AGENTDRAFTED
Definition. PPO clipped surrogate [schulman2017proximal, Section 3, equation (7)] [ftip-003F]AGENTDRAFTED
For a clipping parameter \(\epsilon _{\mathrm {clip}}\in (0,1)\), define \(\operatorname {clip}_{\epsilon _{\mathrm {clip}}}(u) =\min (1+\epsilon _{\mathrm {clip}},\max (1-\epsilon _{\mathrm {clip}},u))\). The PPO clipped surrogate is
\[ L^{\mathrm {CLIP}}(\theta ) =\widehat {\mathbb E}_t\left [ \min \left ( \rho _t(\theta )\widehat A_t, \operatorname {clip}_{\epsilon _{\mathrm {clip}}}(\rho _t(\theta )) \widehat A_t \right )\right ]. \]Clipping changes the sampled surrogate when the ratio moves outside the declared interval in a direction favored by the estimated advantage. It is not a hard bound on the KL divergence of the complete updated policy.
Definition. PPO value-and-entropy objective [schulman2017proximal, Section 5, equation (9)] [ftip-003G]AGENTDRAFTED
Definition. PPO value-and-entropy objective [schulman2017proximal, Section 5, equation (9)] [ftip-003G]AGENTDRAFTED
PPO implementations may optimize the combined sampled objective
\[ \widehat {\mathbb E}_t\left [ L_t^{\mathrm {CLIP}}(\theta ) -c_1\bigl (V_\theta (\mathsf H_t)-\widehat G_t\bigr )^2 +c_2\,\mathcal H\left (\pi _\theta (\cdot \mid \mathsf H_t)\right ) \right ], \]Here \(L_t^{\mathrm {CLIP}}\) is the per-sample integrand of the clipped surrogate in Definition [ftip-003F], \(c_1,c_2\geq 0\), \(\widehat G_t\) is the declared value target, and, on the declared finite or countable discrete action set,
\[ \mathcal H(p)=-\sum _a p(a)\log p(a). \]The combined objective is used only when this nonnegative countable sum is finite, with \(0\log 0=0\). For a continuous action law, an implementation must instead declare a reference measure and the corresponding density-based entropy convention.
The value loss and entropy bonus change the shared-parameter update in addition to the clipped policy term. Their coefficients, target construction, and action space are part of the optimization method.
Definition. PPO rollout and minibatch update [schulman2017proximal, Section 5] [ftip-003H]AGENTDRAFTED
Definition. PPO rollout and minibatch update [schulman2017proximal, Section 5] [ftip-003H]AGENTDRAFTED
A PPO iteration collects a batch of trajectories under the behavior policy, computes returns or advantage estimates, and then performs several epochs of minibatch optimization on the same collected batch. The updated policy becomes the behavior policy for a later collection round.
The number of trajectories, epochs, minibatches, and optimizer steps governs how often one batch is reused. The clipped objective does not determine those protocol choices by itself.
Example. The PPO clipping cases for positive and negative advantage [ftip-003I]AGENTDRAFTED
Example. The PPO clipping cases for positive and negative advantage [ftip-003I]AGENTDRAFTED
Positive and negative advantages select different branches of the PPO clipped minimum.
With \(\epsilon =0.2\), write \(\bar r=\operatorname {clip}(r,0.8,1.2)\) and \(L(r,A)=\min (rA,\bar rA)\). For positive advantage and \(r=1.4\), the gain is capped at \(2.4\). For negative advantage and \(r=0.6\), the clipped term \(-1.6\) is smaller than \(-1.2\), so the objective retains the penalty.
The pointwise surrogate comes from [schulman2017proximal, Section 3]. The two sign cases check only its arithmetic; they provide no monotone-improvement result for a neural policy or finite minibatch.
Example. The InstructGPT-style RLHF pipeline [ftip-003J]AGENTDRAFTED
Example. The InstructGPT-style RLHF pipeline [ftip-003J]AGENTDRAFTED
One prompt passes successively through supervised tuning, comparison-based reward modeling, and PPO in the InstructGPT-style RLHF pipeline.
For the displayed illustrative prompt, suppose the comparison-trained reward model scores the preferred response by \(0.8\). If the candidate policy assigns it twice the probability assigned by the reference policy and the declared KL coefficient is \(\beta =0.1\), its shaped scalar is \[ 0.8-\beta \log \frac {\pi (y_B\mid x)} {\pi _{\rm ref}(y_B\mid x)} =0.8-0.1\log 2\approx 0.731. \]
The stage ordering is grounded in [ouyang2022training, Sections 3.1--3.5]; the numbers are a schematic calculation rather than reported InstructGPT hyperparameters. The diagram records the interface used in that pipeline. Other RLHF systems may order or replace the stages differently.
Remark. PPO is an optimizer, not an alignment definition [ftip-003K]AGENTDRAFTED
Remark. PPO is an optimizer, not an alignment definition [ftip-003K]AGENTDRAFTED
RLHF is a feedback-and-training pipeline; PPO is one optimizer used within that pipeline. PPO specifies a sampled update surrogate; it does not specify whose preferences are collected, what the reward means, or which independent behavior counts as aligned.
Changing the comparison population or reward model can change the alignment target while leaving PPO unchanged. Conversely, replacing PPO by another optimizer changes update geometry without necessarily changing the declared preference data or evaluation criterion.
Direct Preference Optimization [ftip-003L]AGENTDRAFTED
Direct Preference Optimization [ftip-003L]AGENTDRAFTED
Direct Preference Optimization rewrites a KL-regularized reward objective as a policy loss on preference pairs. The derivation proceeds through an optimal-policy identity, a reward--policy reparameterization, and a Bradley--Terry comparison probability. Keeping those steps separate makes its assumptions and its difference from reward-model PPO visible.
Notation. Temperature and reference-policy log ratios [ftip-003M]AGENTDRAFTED
Notation. Temperature and reference-policy log ratios [ftip-003M]AGENTDRAFTED
Let \(\beta >0\) be the KL coefficient, \(\pi _{\mathrm {ref}}\) a fixed reference policy, and \(\pi _\theta \) a trainable policy with support contained in that of the reference on the responses under study. Define the reference-relative log likelihood
\[ \ell _\theta (x,y) =\log \frac {\pi _\theta (y\mid x)}{\pi _{\mathrm {ref}}(y\mid x)} \]and, for a comparison observation, the paired difference
\[ \Delta _\theta (x,y^+,y^-) =\ell _\theta (x,y^+)-\ell _\theta (x,y^-). \]
Definition. Direct preference training stage [rafailov2023direct, Section 4] [ftip-003N]AGENTDRAFTED
Definition. Direct preference training stage [rafailov2023direct, Section 4] [ftip-003N]AGENTDRAFTED
Direct preference training starts from a fixed reference policy and a dataset of preferred and dispreferred responses. It evaluates a binary cross-entropy loss formed from the trainable policy's reference-relative log likelihoods and updates the policy directly.
This stage does not separately fit a scalar reward network, sample online rollouts for PPO, or train a value function. Its loss nevertheless comes from a particular reward-model and KL-regularized optimization derivation.
Definition. Optimal KL-regularized policy [rafailov2023direct, Section 4, equation (4)] [ftip-003O]AGENTDRAFTED
Definition. Optimal KL-regularized policy [rafailov2023direct, Section 4, equation (4)] [ftip-003O]AGENTDRAFTED
For a reward \(r(x,y)\), reference policy \(\pi _{\mathrm {ref}}\), and \(\beta >0\), the optimizer of the per-prompt KL-regularized reward objective has the form
\[ \pi _r(y\mid x) =\frac {1}{Z_r(x)}\, \pi _{\mathrm {ref}}(y\mid x) \exp \left (\frac {r(x,y)}{\beta }\right ), \]where
\[ Z_r(x)=\sum _y\pi _{\mathrm {ref}}(y\mid x) \exp \left (\frac {r(x,y)}{\beta }\right ) \]normalizes the policy on the response space. The identity assumes that the normalizer is finite and uses the same reference policy as the underlying objective.
Definition. Reward--policy reparameterization [rafailov2023direct, Section 4, equation (5)] [ftip-003P]AGENTDRAFTED
Definition. Reward--policy reparameterization [rafailov2023direct, Section 4, equation (5)] [ftip-003P]AGENTDRAFTED
Rearranging the optimal-policy identity of Definition [ftip-003O] gives
\[ r(x,y) =\beta \log \frac {\pi _r(y\mid x)}{\pi _{\mathrm {ref}}(y\mid x)} +\beta \log Z_r(x). \]The final term depends on the prompt but not on the response. It cancels from pairwise reward differences, matching the additive non-identifiability of Bradley--Terry scores described in Remark [ftip-002S].
Definition. Policy-ratio preference probability [rafailov2023direct, Section 4, equation (6)] [ftip-003Q]AGENTDRAFTED
Definition. Policy-ratio preference probability [rafailov2023direct, Section 4, equation (6)] [ftip-003Q]AGENTDRAFTED
Substituting the reward--policy reparameterization into the Bradley--Terry law yields
\[ \Pr _\theta (y^+\succ y^-\mid x) =\sigma \left (\beta \, \Delta _\theta (x,y^+,y^-) \right ), \]where \(\Delta _\theta \) is defined in Notation [ftip-003M]. The prompt-dependent normalizer cancels because the two responses share the same prompt.
Definition. Direct Preference Optimization loss [rafailov2023direct, Section 4, equation (7)] [ftip-003R]AGENTDRAFTED
Definition. Direct Preference Optimization loss [rafailov2023direct, Section 4, equation (7)] [ftip-003R]AGENTDRAFTED
For comparison observations from \(\mathcal D_{\mathrm {pref}}\), the Direct Preference Optimization loss is
\[ L_{\mathrm {DPO}}(\theta ) =-\mathbb E_{(x,y^+,y^-,j)\sim \mathcal D_{\mathrm {pref}}} \left [ \log \sigma \left (\beta \, \Delta _\theta (x,y^+,y^-) \right ) \right ]. \]The empirical loss is evaluated on a fixed comparison dataset. The temperature, reference policy, record weights, and handling of ties or abstentions are part of the training specification.
Example. A Direct Preference Optimization log-ratio calculation [ftip-003S]AGENTDRAFTED
Example. A Direct Preference Optimization log-ratio calculation [ftip-003S]AGENTDRAFTED
Four declared policy probabilities determine the log-ratio margin in one DPO loss term.

Let \(\pi _\theta (y^+\mid x)=0.6\), \(\pi _{\rm ref}(y^+\mid x)=0.3\), \(\pi _\theta (y^-\mid x)=0.2\), and \(\pi _{\rm ref}(y^-\mid x)=0.4\). With \(\beta =1/2\), the DPO logit is \[ z=\beta \left [\log 2-\log (1/2)\right ] =\tfrac 12\log 4=\log 2. \] Hence \(\sigma (z)=2/3\) and the one-pair negative log-likelihood is \(-\log \sigma (z)=\log (3/2)\approx 0.405\).
Substitution into Equation (7) of [rafailov2023direct, Section 4] verifies one loss term. Consistency of the pairwise data, suitability of the reference policy, and improvement in independent utility are separate questions.
Remark. Assumptions behind the DPO derivation [rafailov2023direct, Section 4 and Appendix A.1--A.2] [ftip-003T]AGENTDRAFTED
Remark. Assumptions behind the DPO derivation [rafailov2023direct, Section 4 and Appendix A.1--A.2] [ftip-003T]AGENTDRAFTED
The derivation uses a fixed reference policy, a finite KL-regularized optimum, and a Bradley--Terry model for pairwise preferences. The relevant policy probabilities must be positive wherever their logarithmic ratios are evaluated.
The algebra eliminates the prompt-dependent reward offset, not every source of reward-model misspecification. Heterogeneous or nontransitive preferences, adaptive data collection, support mismatch, and finite-sample optimization remain separate questions.
Remark. How DPO differs from reward-model PPO [rafailov2023direct, Sections 3--4] [ftip-003U]AGENTDRAFTED
Remark. How DPO differs from reward-model PPO [rafailov2023direct, Sections 3--4] [ftip-003U]AGENTDRAFTED
DPO optimizes a policy directly on a fixed preference dataset. Reward-model PPO instead fits an explicit scalar reward predictor, generates policy rollouts, estimates advantages, and applies a policy-gradient update. DPO therefore removes the separately represented reward and online PPO loop from that training stage.
The methods still share ingredients: comparison data, a reference policy, a KL coefficient or temperature, and assumptions connecting comparisons with latent reward. Neither method defines preference optimization in general, and their data and compute requirements are not causally interchangeable.
Outcome and process feedback [ftip-003V]AGENTDRAFTED
Outcome and process feedback [ftip-003V]AGENTDRAFTED
A completed response can receive one terminal judgment, while its intermediate steps can receive separate judgments. These feedback structures support different credit assignments. They must also be distinguished from signals that are actually available online before later steps are observed.
Definition. Outcome-supervised reward model [lightman2023verify, Section 2.5, ``Outcome-supervised reward models''] [ftip-003W]AGENTDRAFTED
Definition. Outcome-supervised reward model [lightman2023verify, Section 2.5, ``Outcome-supervised reward models''] [ftip-003W]AGENTDRAFTED
An outcome-supervised reward model assigns a score to a complete response and is trained from labels attached to the final outcome. For a prompt \(x\) and completed response \(y\), write its score as
\[ r_{\mathrm {out},\phi }(x,y)\in \mathbb R. \]The training label states whether the completed solution reaches the declared outcome. It need not identify the first invalid step or distinguish a sound derivation from an answer reached for an unsound reason.
Definition. Process-supervised reward model [lightman2023verify, Section 2.6, ``Process-supervised reward models''] [ftip-003X]AGENTDRAFTED
Definition. Process-supervised reward model [lightman2023verify, Section 2.6, ``Process-supervised reward models''] [ftip-003X]AGENTDRAFTED
Suppose a response is segmented into reasoning steps \(y=(s_1,\ldots ,s_m)\). A process-supervised reward model produces a score for each declared prefix,
\[ r_{\mathrm {proc},\phi }(x,s_{\leq k})\in \mathbb R, \qquad 1\leq k\leq m, \]and is fitted from step-level labels. The segmentation rule and label semantics are part of the supervision: a score after step \(k\) need not be a decomposition of an outcome score for the whole response.
Remark. Terminal and intermediate supervision [lightman2023verify, Sections 2.5--2.6] [ftip-003Y]AGENTDRAFTED
Remark. Terminal and intermediate supervision [lightman2023verify, Sections 2.5--2.6] [ftip-003Y]AGENTDRAFTED
Outcome supervision uses one completed-response label, whereas process supervision supplies labels at declared intermediate steps. The latter can localize feedback, but it also requires a segmentation, a step-labeling criterion, and additional annotations.
Neither label type is automatically causal credit. A process label may be assigned after a reviewer has seen the whole response, and a terminal outcome may be predicted reliably from an early prefix without identifying which action should change.
Definition. Online measurable feedback [ftip-003Z]AGENTDRAFTED
Definition. Online measurable feedback [ftip-003Z]AGENTDRAFTED
Let \(\mathcal F_t\) be the sigma-algebra generated by the public history \(\mathsf H_t\) available through decision time \(t\). A feedback variable \(Z_t\) is online measurable at time \(t\) when it is \(\mathcal F_t\)-measurable and is delivered before the protocol chooses its next action.
A label computed only after observing a later action or terminal outcome is not online measurable at the earlier time, even if it is subsequently attached to that earlier prefix in the training data.
Remark. Label timing and non-anticipating feedback [ftip-0040]AGENTDRAFTED
Remark. Label timing and non-anticipating feedback [ftip-0040]AGENTDRAFTED
The index attached to a label does not determine when its information becomes available. The process-supervision construction in [lightman2023verify, Section 2.6] supplies step-indexed training labels, but it does not require every such label to be available while the response is being generated.
This distinction determines which interventions are admissible. An online agent may act on currently measurable feedback; an offline learner may use a post-hoc label for a past prefix; a causal claim needs assumptions connecting either signal to the consequences of the earlier action.
Example. Terminal and process labels on the same four-step trace [ftip-0041]AGENTDRAFTED
Example. Terminal and process labels on the same four-step trace [ftip-0041]AGENTDRAFTED
A four-step arithmetic trace can receive a correct terminal label while retaining an incorrect intermediate process label.
The final answer \(19\) is correct, so outcome supervision supplies \(f_{\rm out}=1\). The declared process labels are \((f_1,f_2,f_3,f_4)=(1,1,0,1)\) and expose the corrected arithmetic error at step three. The labels are attached to the displayed prefixes, which remain unchanged by those annotations.
The two supervision regimes follow the outcome- and process-supervised reward-model constructions in [lightman2023verify, the outcome- and process-supervised reward-model subsections]. The two observations are thereby separated. Noise-free labels and a general policy advantage for process supervision are not consequences of the finite trace.
Reinforcement learning with verifiable rewards [ftip-0042]AGENTDRAFTED
Reinforcement learning with verifiable rewards [ftip-0042]AGENTDRAFTED
Reinforcement learning with verifiable rewards replaces or supplements a learned judge with a declared check of the generated result. Contemporary methods differ in their verifier, sampling law, advantage estimator, clipping, normalization, and treatment of length. This section defines those choices separately before they are assembled into a training protocol.
Notation. Verifiers, evidence, rollout groups, and group statistics [ftip-0043]AGENTDRAFTED
Notation. Verifiers, evidence, rollout groups, and group statistics [ftip-0043]AGENTDRAFTED
Let \(\mathcal E\) be an evidence space. Write \(\mathsf V\) for a declared verifier, \(e_{\mathrm {ver}}\in \mathcal E\) for its evidence, \(d_{\mathrm {ver}}\in \{0,1\}\) for its decision, and \(R_{\mathrm {ver}}\in \mathbb R\) for the reward derived from that result.
For a prompt \(x\) and group size \(g\geq 2\), write \(\mathbf Y_x=(Y^{(1)},\ldots ,Y^{(g)})\) for a rollout group sampled from the behavior policy. Let \(R_i\) be the reward of member \(i\), \(\bar R\) the group mean, \(S_R\) the group standard deviation, and \(\widehat A_i\) its group-relative advantage.
Definition. Reinforcement learning with verifiable rewards [lambert2024tulu3, Section 6, equations (7)--(8), and the paragraph following equation (8)] [ftip-0044]AGENTDRAFTED
Definition. Reinforcement learning with verifiable rewards [lambert2024tulu3, Section 6, equations (7)--(8), and the paragraph following equation (8)] [ftip-0044]AGENTDRAFTED
Reinforcement learning with verifiable rewards is a post-training method that samples responses from a language-model policy, computes rewards with a deterministic check of the response, and applies a reinforcement-learning update to increase expected checked reward, optionally with regularization to a reference policy.
In the cited construction, a correct response receives reward \(\alpha \) and an incorrect response receives \(0\). Equation (8) gives this two-valued form, and the paragraph immediately after it sets \(\alpha =10\). The checked predicate, reward scale, prompt law, rollout procedure, and policy optimizer remain separate parts of the method.
Remark. RLVR sampling, feedback, and update rules [ftip-0045]AGENTDRAFTED
Remark. RLVR sampling, feedback, and update rules [ftip-0045]AGENTDRAFTED
Concrete RLVR methods include the PPO-based construction in [lambert2024tulu3, Section 6], group relative policy optimization (GRPO) in [shao2024deepseekmath, Section 4.1], R1-Zero in [guo2025deepseek, Section 2.2], and Decoupled Clip and Dynamic sAmpling Policy Optimization (DAPO) in [yu2025dapo, Sections 2--3].
A proposed common description groups methods that acquire policy samples, evaluate a declared verifiable signal, assign credit, and update the policy. A specific claim must still name its verifier, group sampling, estimator, clipping, normalization, reference-policy treatment, and length rule.
Definition. Verifier correctness indicator [ftip-0046]AGENTDRAFTED
Definition. Verifier correctness indicator [ftip-0046]AGENTDRAFTED
For prompts and responses from Notation [ftip-002A], a deterministic verifier correctness indicator is a declared map
\[ v:\{(x,y):x\in \mathcal X_{\mathrm {pr}},\ y\in \mathcal Y(x)\} \longrightarrow \{0,1\}, \]Here \(v(x,y)=1\) means that the response satisfies the checked predicate. The map includes the parsing and execution rules needed to reproduce the decision. A stochastic judge or learned reward model is a different feedback mechanism unless its randomness and decision procedure are separately exposed.
Definition. Verifier evidence [ftip-0047]AGENTDRAFTED
Definition. Verifier evidence [ftip-0047]AGENTDRAFTED
A verifier evidence record is a tuple
\[ e_{\mathrm {ver}}=(\iota _{\mathrm {ver}},x,y,o,d_{\mathrm {ver}}), \]where \(\iota _{\mathrm {ver}}\) identifies the verifier and its version, \(o\) is the reproducible output used by the check, and \(d_{\mathrm {ver}}\in \{0,1\}\) is the resulting decision. Examples of \(o\) include a parsed exact answer, a test log, or a proof-checker result.
The evidence record preserves how the decision was obtained. It does not assert that the checked predicate is complete for the task's independent success criterion.
Remark. A decision and reproducible evidence are distinct [ftip-0048]AGENTDRAFTED
Remark. A decision and reproducible evidence are distinct [ftip-0048]AGENTDRAFTED
The same correctness decision can arise from different parsers, tests, proof kernels, or failure modes. Tülu 3 uses a scaled two-valued reward \(\alpha \) or \(0\), with \(\alpha =10\), in [lambert2024tulu3, Section 6, equation (8), and the immediately following paragraph]; it does not identify that reward with a complete record of the checking procedure.
Evidence enables later audits of false positives, false negatives, version changes, and shortcut exploitation. Reproducibility of the check still does not establish that the checked predicate equals the intended capability.
Definition. Verifiable reward [lambert2024tulu3, Section 6, equation (8), and the immediately following paragraph] [ftip-0049]AGENTDRAFTED
Definition. Verifiable reward [lambert2024tulu3, Section 6, equation (8), and the immediately following paragraph] [ftip-0049]AGENTDRAFTED
Given a deterministic correctness indicator \(v\) and reward scale \(\alpha >0\), the verifiable reward in the cited construction is
\[ R_{\mathrm {ver}}(x,y)= \begin {cases} \alpha ,&v(x,y)=1,\\ 0,&v(x,y)=0. \end {cases} \]The paragraph after Equation (8) sets \(\alpha =10\). Another method may choose a different scale or combine several checked components, but that transformation is part of its reward design. A reward is verifiable relative to the implemented check, not relative to every property an independent evaluator may care about.
Remark. Rule, test, and proof evidence [ftip-004A]AGENTDRAFTED
Remark. Rule, test, and proof evidence [ftip-004A]AGENTDRAFTED
Rule evidence compares a parsed answer or format with a declared target, as in [guo2025deepseek, Section 2.2]. Test evidence executes a candidate in a sandbox and records test outcomes. Proof evidence submits a term to a specified checker and records acceptance or an error.
These routes expose different predicates and costs. A rule can ignore the derivation, a test suite can omit behavior, and a proof checker establishes only the proposition and trusted-kernel boundary it was given. Their rewards must not be merged without retaining which evidence source fired.
Definition. Rollout group [shao2024deepseekmath, Section 4.1.2] [ftip-004B]AGENTDRAFTED
Definition. Rollout group [shao2024deepseekmath, Section 4.1.2] [ftip-004B]AGENTDRAFTED
Fix a prompt \(x\), group size \(g\geq 2\), and behavior policy \(\pi _b\). A rollout group is the indexed family
\[ \mathbf Y_x=(Y^{(1)},\ldots ,Y^{(g)}), \qquad Y^{(i)}\sim \pi _b(\mathord \cdot \mid x). \]DeepSeekMath samples several outputs for the same prompt so their rewards can define a group-relative baseline. The producing policy, decoder, group size, and conditional sampling dependence are part of the rollout law.
Definition. Group mean and standard deviation [shao2024deepseekmath, Section 4.1.2] [ftip-004C]AGENTDRAFTED
Definition. Group mean and standard deviation [shao2024deepseekmath, Section 4.1.2] [ftip-004C]AGENTDRAFTED
For rollout-group rewards \(R_1,\ldots ,R_g\), define the group mean and group standard deviation by
\[ \bar R=\frac 1g\sum _{i=1}^g R_i, \qquad S_R=\operatorname {std}(R_1,\ldots ,R_g). \]Both statistics are prompt-local and depend on every member of the sampled group. The source leaves the standard-deviation divisor symbolic and does not add a numerical stabilizer. An implementation must state those conventions and its treatment of zero-variance groups.
Definition. Group-relative advantage [shao2024deepseekmath, Section 4.1.2] [ftip-004D]AGENTDRAFTED
Definition. Group-relative advantage [shao2024deepseekmath, Section 4.1.2] [ftip-004D]AGENTDRAFTED
When \(S_R>0\), the group-relative advantage of rollout member \(i\) is
\[ \widehat A_i=\frac {R_i-\bar R}{S_R}. \]The estimator compares responses sampled for the same prompt and does not require a learned value function. Its members are statistically coupled through \(\bar R\) and \(S_R\); it is not an independent estimate of the population advantage of each response.
Definition. Outcome-supervision GRPO [shao2024deepseekmath, Section 4.1.2] [ftip-004E]AGENTDRAFTED
Definition. Outcome-supervision GRPO [shao2024deepseekmath, Section 4.1.2] [ftip-004E]AGENTDRAFTED
Outcome-supervision GRPO samples a group of responses for one prompt, assigns each response an outcome reward, standardizes those rewards within the group, and uses the resulting group-relative advantage across the response's token log-likelihood terms.
The construction removes a separately learned critic but retains a behavior policy, likelihood ratios, a reference-policy term in the source formulation, and explicit normalization choices.
Definition. Process-supervision GRPO [shao2024deepseekmath, Section 4.1.3] [ftip-004F]AGENTDRAFTED
Definition. Process-supervision GRPO [shao2024deepseekmath, Section 4.1.3] [ftip-004F]AGENTDRAFTED
Process-supervision GRPO supplies rewards at declared reasoning steps and forms advantages from the subsequent step rewards assigned to each token. The policy objective therefore receives credit that can vary within one response rather than repeating one terminal outcome advantage at every token.
This construction requires a step segmentation and a process reward model. Its estimator is not obtained merely by relabeling an outcome-supervision rollout group.
Remark. GRPO variants and estimator conventions [shao2024deepseekmath, Section 4.1] [ftip-004G]AGENTDRAFTED
Remark. GRPO variants and estimator conventions [shao2024deepseekmath, Section 4.1] [ftip-004G]AGENTDRAFTED
GRPO names a family of group-relative policy updates rather than one fully determined estimator. Outcome and process supervision assign different reward structures. Implementations may also differ in token versus response normalization, KL terms, clipping intervals, importance weights, and treatment of groups with zero reward variance.
A result about one variant must retain its producing policy and all of those conventions. Sharing the group-relative baseline does not make the resulting gradients identical.
Definition. DAPO clip-higher [yu2025dapo, Section 3.1] [ftip-004H]AGENTDRAFTED
Definition. DAPO clip-higher [yu2025dapo, Section 3.1] [ftip-004H]AGENTDRAFTED
Clip-higher replaces the symmetric upper and lower PPO clipping widths by separate constants. It permits a larger upward likelihood-ratio movement for tokens with positive advantage while retaining a smaller lower-side interval.
The change alters which sampled terms are saturated by the surrogate. It does not impose a policy-wide trust region or guarantee preservation of low-probability actions.
Definition. Dynamic sampling [yu2025dapo, Section 3.2] [ftip-004I]AGENTDRAFTED
Definition. Dynamic sampling [yu2025dapo, Section 3.2] [ftip-004I]AGENTDRAFTED
DAPO dynamic sampling filters prompt groups whose sampled responses all receive the same reward and continues sampling until the training batch contains the declared number of groups with nonzero reward variation.
The intervention changes the distribution of prompts and rollouts entering the update. It can prevent zero-advantage groups from consuming an optimizer batch, but the retained batch is no longer an unconditioned sample from the original prompt law.
Definition. Token-level policy-gradient loss [yu2025dapo, Section 3.3] [ftip-004J]AGENTDRAFTED
Definition. Token-level policy-gradient loss [yu2025dapo, Section 3.3] [ftip-004J]AGENTDRAFTED
The token-level loss aggregates active token terms across the complete minibatch and divides by the number of active tokens. A longer response therefore contributes in proportion to its active token count rather than receiving the same total weight as every shorter response.
This normalization changes the empirical gradient even when the sampled responses, rewards, advantages, and likelihood ratios are unchanged. It must be distinguished from averaging a separately normalized loss over responses.
Definition. Overlong reward shaping [yu2025dapo, Section 3.4] [ftip-004K]AGENTDRAFTED
Definition. Overlong reward shaping [yu2025dapo, Section 3.4] [ftip-004K]AGENTDRAFTED
Overlong reward shaping introduces a soft penalty near the maximum response length before the hard truncation boundary. The penalty increases over a declared buffer region rather than assigning the same abrupt terminal penalty to every response that reaches the limit.
The construction changes both the reward value and which length-related behavior receives gradient. The maximum length, buffer width, and penalty schedule are part of the reward design.
Remark. These interventions change sampling and reward geometry [yu2025dapo, Sections 3.1--3.4] [ftip-004L]AGENTDRAFTED
Remark. These interventions change sampling and reward geometry [yu2025dapo, Sections 3.1--3.4] [ftip-004L]AGENTDRAFTED
Clip-higher changes the saturated region of the policy surrogate, dynamic sampling conditions which prompt groups enter a batch, token-level aggregation changes response-length weighting, and overlong shaping changes the reward near a truncation boundary. These are four different interventions.
An observed training improvement cannot be assigned to a generic ``algorithm'' without an ablation that holds the other sampling, estimator, reward, and compute choices fixed. The interventions also change which rollouts and gradients are observed, so their effects need not add linearly.
Example. One response-level RLVR round [ftip-004M]AGENTDRAFTED
Example. One response-level RLVR round [ftip-004M]AGENTDRAFTED
Three sampled responses pass through exact verification, group credit, and a proposed update in one finite RLVR round.
The exact-answer checker gives mean reward \(\bar r=2/3\). Using the declared unnormalized centered credit \(\widehat A_i=r_i-\bar r\) yields \((1/3,-2/3,1/3)\). An optimizer may use these numbers to propose a parameter change, but the tuple itself is not yet an accepted update.
The RLVR protocol is Definition [ftip-0044]. Its group-credit objects are Definition [ftip-004B], Definition [ftip-004C], and Definition [ftip-004D]. Together they specialize to this finite order of operations. Centered, unscaled credit and an exact-answer checker are local choices rather than requirements on other RLVR algorithms.
Example. Four rollout rewards, group advantages, and clipping [ftip-004N]AGENTDRAFTED
Example. Four rollout rewards, group advantages, and clipping [ftip-004N]AGENTDRAFTED
A rollout group is normalized to relative advantages and then passed to a clipped surrogate objective.

For a rollout group with rewards \(r_i\), form a group mean and scale and set \(\widehat A_i=(r_i-\bar r)/s\). For current-to-behaviour ratios \(\rho _i\) and clip interval \([1-\epsilon ,1+\epsilon ]\), define each pointwise term by
\[ \begin {aligned} \ell _i=\min \{&\rho _i\widehat A_i,\\ &\operatorname {clip}(\rho _i,1-\epsilon ,1+\epsilon )\widehat A_i\}. \end {aligned} \]The mean of the resulting terms is the group contribution to the update; its value depends on the sampled rewards, ratios, and clip width.
Group-relative normalization is grounded in [shao2024deepseekmath, Section 4.1], while clipping is grounded in [schulman2017proximal, Section 3]. The normalization convention and ratios must be declared by the training protocol; a positive surrogate mean alone gives no guarantee of improved held-out performance after an optimizer step.
Agentic post-training [ftip-004O]AGENTDRAFTED
Agentic post-training [ftip-004O]AGENTDRAFTED
Response-level training ends when a model emits an answer. Agentic post-training also trains decisions made after observations from tools or other external systems.
Definition. Action serializer [ftip-004P]AGENTDRAFTED
Definition. Action serializer [ftip-004P]AGENTDRAFTED
Fix the token vocabulary and strings of the tokenizer interface, and the action space \(\mathcal A\) from the declared interactive task realization. An action serializer is a pair of partial maps
\[ \operatorname {enc}:\mathcal A\rightharpoonup \mathcal V^*, \qquad \operatorname {dec}:\mathcal V^*\rightharpoonup \mathcal A. \]The encoder gives an action a textual representation. The decoder recognizes a completed representation and returns the executable action. A string outside the decoder's domain is malformed; it is not silently promoted to an environment action. For every action in the encoder's domain, the declared pair satisfies \(\operatorname {dec}(\operatorname {enc}(a))=a\).
Remark. Generated tokens and executable actions [ftip-004Q]AGENTDRAFTED
Remark. Generated tokens and executable actions [ftip-004Q]AGENTDRAFTED
An action serializer maps generated text to an executable action. Section 2 of ReAct: Synergizing reasoning and acting in language models[yao2023react] writes actions and observations in a textual trajectory. The proposed serializer interface in Definition [ftip-004P] additionally distinguishes malformed calls, constrained grammars, and environment actions.
An improvement can therefore come from better reasoning, better serialization, or a more permissive parser. These are separate intervention coordinates.
Definition. tool interaction [yao2023react, Section 2] [ftip-004R]AGENTDRAFTED
Definition. tool interaction [yao2023react, Section 2] [ftip-004R]AGENTDRAFTED
A ReAct interaction alternates model-generated reasoning and actions with observations returned by an external interface. The observation is appended to the next model context, so subsequent actions may depend on earlier tool results.
A decoded action belongs to \(\mathcal A\) in the declared interactive task realization; the transition--observation kernel of Definition [ftip-001Z] returns the next observation. The cited construction does not by itself fix a sandbox, reward, or training algorithm.
Definition. Sandbox [ftip-004S]AGENTDRAFTED
Definition. Sandbox [ftip-004S]AGENTDRAFTED
Fix an interactive realization \(\mathsf {Env}_{\mathsf T}\) from the declared task interface, a measurable evidence space \(\mathcal E_{\rm box}\), and a cost dimension \(m\geq 1\). A sandbox specifies an allowed action set \(\mathcal A^{\rm box}_{\mathsf T}\subseteq \mathcal A_{\mathsf T}\) that is measurable, a cost bound \(b_{\rm box}\in \mathbb R_+^m\), and, for each \(x\in \mathcal X_{\mathsf T}\) and \(0\leq t<T_{\max }\), an execution kernel
\[ K_{t}^{\rm box,x}: \mathcal S_{\mathsf T}\times \mathcal A^{\rm box}_{\mathsf T} \rightsquigarrow \mathcal S_{\mathsf T}\times \mathcal O^{\rm obs}_{\mathsf T} \times \mathcal E_{\rm box}\times \mathbb R_+^m, \]It also specifies, for each \(x\in \mathcal X_{\mathsf T}\), a reset kernel
\[ \mathsf {Reset}^{x}_{\rm box}:\{\ast \}\rightsquigarrow \mathcal S_{\mathsf T}\times \mathcal O^{\rm obs}_{\mathsf T} \times \mathcal E_{\rm box}\times \mathbb R_+^m. \]For an allowed action, the state--observation marginal of \(K_t^{\rm box,x}\) is the kernel \(K_t^x\) in the task realization; the state--observation marginal of the reset kernel is \(\rho _0^x\). The remaining coordinates record reproducible evidence and a realized cost increment. An admitted stopped trajectory must have componentwise cumulative cost at most \(b_{\rm box}\).
The sandbox semantics include permissions, kernel and reset versions, evidence encoding, and cost accounting. A tool name or API schema alone does not determine these fields.
Remark. Sandbox restrictions and trajectory laws [ftip-004T]AGENTDRAFTED
Remark. Sandbox restrictions and trajectory laws [ftip-004T]AGENTDRAFTED
A sandbox restricts the environment through its executor, reset rules, permissions, and evidence. ReAct [yao2023react, Section 2] supplies the action--observation pattern. Software-agent systems surveyed in [wang2024agents, Section 2.3.2] add repositories, compilers, tests, and other digital tools. The combined sandbox interface is a proposed model of these choices.
Two protocols that share prompts but change reset or permission semantics need not induce the same trajectory law.
Definition. Agentic post-training state [ftip-004U]AGENTDRAFTED
Definition. Agentic post-training state [ftip-004U]AGENTDRAFTED
Let \(\mathcal M_{\rm exec}\) be the space of executable model artifacts, \(\mathcal Z_{\rm opt}\) the optimizer-state space, and \(\mathcal R_{\rm ag}\) a declared space of typed agentic round records. At training round \(n\), an agentic post-training state is a tuple \[ \Sigma _n=(M_n,s_n,\mathcal L_n) \in \mathcal M_{\rm exec}\times \mathcal Z_{\rm opt} \times \mathcal R_{\rm ag}^{n}, \] where \(M_n\) is the executable model artifact, \(s_n\) is the optimizer state, and \(\mathcal L_n=(r_0,\ldots ,r_{n-1})\) is an append-only training ledger.
The round-record schema records the task and instance draw, policy and inference stamp, environment version, stopped trajectory, feedback and credit outputs, update decision, proposed and committed next artifact and optimizer state, random seeds, operator versions, and realized cost vector. The tuple separates executable state from optimizer state and from evidence about how that state was reached.
Definition. One agentic post-training round [ftip-0073]AGENTDRAFTED
Definition. One agentic post-training round [ftip-0073]AGENTDRAFTED
At round \(n\), fix a task \(\mathsf T_n\), its law \(\mu _{\mathsf T_n}\), and a versioned interactive realization \(\mathsf {Env}^{\upsilon _n}_{\mathsf T_n}\). Let \(\mathcal I_{\rm art}\) and \(\mathcal I_{\rm inf}\) be declared identifier spaces. Let \(a_n\in \mathcal I_{\rm art}\) be an immutable content identifier resolving the artifact \(M_n\), and let \(\iota _n\in \mathcal I_{\rm inf}\) record all serializer, decoding, tool, and stopping settings. The policy--inference stamp \(\nu _n=(a_n,\iota _n)\in \mathcal I_{\rm art}\times \mathcal I_{\rm inf}\) resolves a non-anticipating policy \(\pi _n\). Let \(\Omega _n^{\rm task}\), \(\Omega _n^{\rm roll}\), \(\Omega _n^{\rm feed}\), \(\Omega _n^{\rm credit}\), and \(\Omega _n^{\rm update}\) be declared seed spaces. The rollout seed contains both policy-decoding and environment randomness. Write \(\Omega _n=\Omega _n^{\rm task}\times \Omega _n^{\rm roll}\times \Omega _n^{\rm feed}\times \Omega _n^{\rm credit}\times \Omega _n^{\rm update}\), and let \(\omega _n=(\omega _n^{\rm task},\omega _n^{\rm roll}, \omega _n^{\rm feed},\omega _n^{\rm credit},\omega _n^{\rm update})\) be sampled from a declared joint law on \(\Omega _n\). Write \(\mathcal Z_{\mathsf T_n}\) for the stopped trajectories admitted by the versioned realization.
For declared feedback and credit spaces \(\mathcal F_n\) and \(\mathcal G_n\), decision space \(\mathcal D_n=\{\mathsf {accept},\mathsf {reject}\}\), accounting dimension \(m\geq 1\), and exact implementation versions \(v_n^{\rm S}\), \(v_n^{\rm R}\), \(v_n^{\rm F}\), \(v_n^{\rm C}\), \(v_n^{\rm U}\), and \(v_n^{\rm A}\), the round specifies maps
\[ \begin {aligned} \mathsf S_n^{v_n^{\rm S}}&: \Omega _n^{\rm task}\longrightarrow \mathcal X_{\mathsf T_n},\\ \mathsf R_n^{v_n^{\rm R}}&: \mathcal X_{\mathsf T_n}\times \Omega _n^{\rm roll} \longrightarrow \mathcal Z_{\mathsf T_n},\\ \mathsf F_n^{v_n^{\rm F}}&: \mathcal X_{\mathsf T_n}\times \mathcal Z_{\mathsf T_n} \times \Omega _n^{\rm feed}\longrightarrow \mathcal F_n,\\ \mathsf C_n^{v_n^{\rm C}}&: \mathcal X_{\mathsf T_n}\times \mathcal Z_{\mathsf T_n} \times \mathcal F_n\times \Omega _n^{\rm credit} \longrightarrow \mathcal G_n,\\ \mathsf U_n^{v_n^{\rm U}}&: \mathcal M_{\rm exec}\times \mathcal Z_{\rm opt}\times \mathcal G_n \times \Omega _n^{\rm update} \longrightarrow \mathcal D_n\times \mathcal M_{\rm exec}\times \mathcal Z_{\rm opt},\\ \mathsf A_n^{v_n^{\rm A}}&: \mathcal M_{\rm exec}\times \mathcal Z_{\rm opt} \times \mathcal X_{\mathsf T_n}\times \mathcal Z_{\mathsf T_n}\\ &\quad {}\times \mathcal F_n\times \mathcal G_n\times \mathcal D_n\\ &\quad {}\times \mathcal M_{\rm exec}\times \mathcal Z_{\rm opt} \times \Omega _n\longrightarrow \mathbb R_+^m. \end {aligned} \]The accounting map receives the starting state, proposed state, decision, and realized seeds, so update work and rejected proposals remain observable in the cost record.
They produce
\[ \begin {aligned} X_n&=\mathsf S_n^{v_n^{\rm S}}(\omega _n^{\rm task}),\\ Z_n&=\mathsf R_n^{v_n^{\rm R}}(X_n,\omega _n^{\rm roll}),\\ F_n&=\mathsf F_n^{v_n^{\rm F}}(X_n,Z_n,\omega _n^{\rm feed}),\\ \Gamma _n&=\mathsf C_n^{v_n^{\rm C}} (X_n,Z_n,F_n,\omega _n^{\rm credit}),\\ (d_n,\widetilde M_{n+1},\widetilde s_{n+1}) &=\mathsf U_n^{v_n^{\rm U}} (M_n,s_n,\Gamma _n,\omega _n^{\rm update}),\\ c_n&=\mathsf A_n^{v_n^{\rm A}}( M_n,s_n,X_n,Z_n,F_n,\Gamma _n,d_n, \widetilde M_{n+1},\widetilde s_{n+1},\omega _n). \end {aligned} \]The task sampler pushes its seed law forward to \(\mu _{\mathsf T_n}\). Conditional on \(X_n\), the rollout sampler pushes its seed law forward to the interaction law of Remark [ftip-0028] under \(\mathsf {Env}^{\upsilon _n}_{\mathsf T_n}\) and \(\pi _n\).
If \(d_n=\mathsf {accept}\), set \((M_{n+1},s_{n+1})=(\widetilde M_{n+1},\widetilde s_{n+1})\); if \(d_n=\mathsf {reject}\), set \((M_{n+1},s_{n+1})=(M_n,s_n)\). The realized cost \(c_n\) includes proposal work even after rejection. With \(v_n^{\rm ops}=(v_n^{\rm S},v_n^{\rm R},v_n^{\rm F},v_n^{\rm C}, v_n^{\rm U},v_n^{\rm A})\), append
\[ \begin {aligned} r_n={}&(\mathsf T_n,X_n,\nu _n,\upsilon _n,Z_n,F_n,\Gamma _n,d_n, \widetilde M_{n+1},\widetilde s_{n+1},M_{n+1},s_{n+1}, \omega _n,v_n^{\rm ops},c_n),\\ \mathcal L_{n+1}={}&\operatorname {append}(\mathcal L_n,r_n). \end {aligned} \]The record belongs to \(\mathcal R_{\rm ag}\) from Definition [ftip-004U] and determines \(\Sigma _{n+1}\) without rewriting an earlier record.
Definition. Agentic post-training run [ftip-0074]AGENTDRAFTED
Definition. Agentic post-training run [ftip-0074]AGENTDRAFTED
An agentic post-training run fixes a finite round count \(N_{\rm ag}\geq 0\), an initial state \(\Sigma _0\), a fixed accounting dimension \(m\geq 1\), a componentwise budget \(b_{\rm ag}\in \mathbb R_+^m\), and the round specifications of Definition [ftip-0073]. Put \(\Omega _{\rm ag}=\prod _{n=0}^{N_{\rm ag}-1}\Omega _n\), using a singleton for the empty product. Once those specifications and their exact versions \(v_{\rm ag}\) are fixed, the run is the map
\[ \mathsf {Run}_{\Sigma _0,v_{\rm ag}}:\Omega _{\rm ag}\longrightarrow \mathcal M_{\rm exec}\times \mathcal R_{\rm ag}^{N_{\rm ag}} \times \mathbb R_+^m. \]Write a realized round-seed tuple as
\[ \omega _{\rm ag}=(\omega _0,\ldots ,\omega _{N_{\rm ag}-1}). \]The run recursively constructs \(\Sigma _1,\ldots ,\Sigma _{N_{\rm ag}}\); the seed tuple and state sequence are empty beyond \(\Sigma _0\) when \(N_{\rm ag}=0\). Its cumulative realized cost is \[ c_{\rm ag}=\sum _{n=0}^{N_{\rm ag}-1}c_n. \] The empty sum is \(0\in \mathbb R_+^m\) when \(N_{\rm ag}=0\). The map returns \((M_{N_{\rm ag}},\mathcal L_{N_{\rm ag}},c_{\rm ag})\). A run claiming the hard budget must declare a pre-admission or stopping rule that guarantees \(c_{\rm ag}\preceq b_{\rm ag}\).
The run declaration includes the task sampler, environments, serializers, rollout inference settings, feedback and credit maps, update maps, stopping rule, seed laws, implementation versions, and resource account. The round records retain every realized seed, version, decision, and cost. Leaving one of these fields implicit defines a family of runs rather than one reproducible intervention.
Remark. Post-training with intermediate observations [ftip-004X]AGENTDRAFTED
Remark. Post-training with intermediate observations [ftip-004X]AGENTDRAFTED
A proposed interactive extension of the response-level RLVR cycle in § [ftip-0042] uses the environment of § [ftip-001W] and the action boundary of Definition [ftip-004P]. It retains intermediate observations and environment state instead of treating a whole response as one indivisible action.
This change introduces new questions about partial observability, long-horizon credit, environment versioning, recovery after interruption, and the cost of external execution. It does not assert that multi-turn training is uniformly better than response-level training.
Example. A short code-agent trace with tool evidence [ftip-004V]AGENTDRAFTED
Example. A short code-agent trace with tool evidence [ftip-004V]AGENTDRAFTED
A failing test observation triggers a second edit, whose passing tool evidence determines the terminal result.
The public history records both edits and both test outputs. The first tool call returns the evidence string expected 9, got 6; the second returns exit status \(0\) and 1 passed. The success rule reads the second test result rather than the model's assertion that its edit is correct.
The action--observation alternation follows the tool-interleaving pattern in [yao2023react, Section 2]. The transparent sandbox interaction certifies only the displayed test result; completeness of the suite and satisfaction of unstated intent remain unverified.
Example. A DeepSeek-family resilient rollout and sandbox schematic [ftip-004W]AGENTDRAFTED
Example. A DeepSeek-family resilient rollout and sandbox schematic [ftip-004W]AGENTDRAFTED
Two coupled panels place resumable generation beside sandbox evidence in a single rollout record.
A write-ahead log and cached state allow a resumable rollout; a sandbox execution contributes a separately recorded evidence tuple. The two records should remain distinguishable when lifecycle cost is audited.
Token-granular write-ahead logging with key--value cache recovery and DeepSeek Elastic Compute (DSec), the report's named sandbox interface, are described in Sections 5.2.3 and 5.2.5 of the DeepSeek-V4 family report [⧉]. The cited sources do not establish that DeepSeek-V4-Flash-0731 used this job, resource limit, rollout schedule, or sandbox configuration.
Feedback, replay, and update control [ftip-004Y]AGENTDRAFTED
Feedback, replay, and update control [ftip-004Y]AGENTDRAFTED
Post-training systems often reuse historical trajectories. This section separates what happened during a rollout from quantities recomputed when that rollout is considered for another update.
Definition. Policy stamp [ftip-004Z]AGENTDRAFTED
Definition. Policy stamp [ftip-004Z]AGENTDRAFTED
A policy stamp \(\nu \) is a content-addressed description of an executable policy: model artifact, tokenizer, action serializer, decoding settings, and implementation revision. Resolving the stamp produces the action law \(\pi ^\nu (\,\cdot \mid \mathsf H_t)\) for every public history in its declared domain.
Two stamps are equal only when every component that may change the action law is equal. A display name or checkpoint step is therefore insufficient.
Remark. Behavior policies and executable-policy identity [ftip-0050]AGENTDRAFTED
Remark. Behavior policies and executable-policy identity [ftip-0050]AGENTDRAFTED
Off-policy methods distinguish the behavior and current policies, while language-model artifacts also depend on tokenization and decoding. Section 3 of When to stop reusing: Dynamic gradient gating for sample-efficient RLVR[miao2026when] records the behavior/current distinction. The additional artifact and implementation fields in the proposed policy stamp make the executable law reproducible.
The stamp identifies an executable law; it does not claim that two implementations with different stamps must behave differently on every task.
Definition. Immutable rollout record [ftip-0051]AGENTDRAFTED
Definition. Immutable rollout record [ftip-0051]AGENTDRAFTED
An immutable rollout record is a tuple
\[R=(q,\nu _b,\tau ,e),\]where \(q\) is the sampled task, \(\nu _b\) is the behavior-policy stamp, \(\tau \) is the stopped trajectory of Definition [ftip-0025], and \(e\) is the verifier evidence of Definition [ftip-0047]. The tuple records facts fixed when the rollout finishes.
Current-policy likelihood ratios, clipping decisions, reuse counts, and acceptance decisions are excluded because they may change on a later update attempt.
Remark. A historical event is not an update attempt [ftip-0052]AGENTDRAFTED
Remark. A historical event is not an update attempt [ftip-0052]AGENTDRAFTED
An immutable historical record prevents an update attempt from rewriting the facts attached to its reused samples. The sample-reuse setup in [miao2026when, Section 3] retains behavior-policy rollouts while recomputing current-policy ratios. Dynamic Gradient Gating (DGG), defined in [miao2026when, Section 5 and Algorithm 1], is one such reuse protocol, while the complete immutable tuple is a proposed interface for such protocols.
Recorded facts and estimates recomputed for an attempted update are different objects; errors in the latter do not alter the former.
Definition. Feedback operator [ftip-0053]AGENTDRAFTED
Definition. Feedback operator [ftip-0053]AGENTDRAFTED
Let \(\mathcal R\) be the set of immutable rollout records and \(\mathcal F\) a typed set of feedback events. A feedback operator is a possibly randomized kernel
\[\mathsf {Feed}:\mathcal R\rightsquigarrow \mathcal F.\]A feedback event may contain an outcome score, step labels, a preference, or an abstention. Its type records which observations were available when it was produced.
Definition. Credit-assignment rule [ftip-0054]AGENTDRAFTED
Definition. Credit-assignment rule [ftip-0054]AGENTDRAFTED
Let \(R\) be a rollout record with \(\tau _{\rm stop}\) actions, and let \(f\) be its feedback event. A credit-assignment rule returns indexed training targets
\[\mathsf {Credit}(R,f)=(c_0,\ldots ,c_{\tau _{\rm stop}-1}).\]Each \(c_t\) is attached to an action or token position declared by the rule. It may be a return, an advantage estimate, a binary label, or a structured target. The rule is distinct from the feedback source that supplied \(f\).
Remark. Observed feedback and assigned credit [ftip-0055]AGENTDRAFTED
Remark. Observed feedback and assigned credit [ftip-0055]AGENTDRAFTED
Terminal returns, process labels, preference observations, and verifier rewards determine what information is observed. A credit rule determines where that information enters an objective. Treating them as separate inputs is a proposed common description of these different methods.
Separating the interfaces permits questions about delayed, noisy, or misallocated credit without changing the underlying evidence.
Definition. Replay pool [ftip-0056]AGENTDRAFTED
Definition. Replay pool [ftip-0056]AGENTDRAFTED
At update index \(n\), a replay pool \(\mathcal R_n\) is a finite multiset of immutable rollout records eligible for selection. Its management rule specifies insertion, eviction, and any partition by task or behavior stamp.
The pool is persistent state of the training protocol. It is not the minibatch selected for one update.
Definition. Attempt-local replay annotation [ftip-0057]AGENTDRAFTED
Definition. Attempt-local replay annotation [ftip-0057]AGENTDRAFTED
Selecting \(R\in \mathcal R_n\) under a current policy stamp \(\nu _n\) produces an attempt-local replay annotation
\[a_n(R)=(\nu _n,\rho ,\kappa ,m,u),\]where \(\rho \) is the declared collection of behavior/current likelihood ratios, \(\kappa \) records clipping status, \(m\) is the record age, and \(u\) is its prior reuse count. Every component is computed for this attempt and may change at the next one.
Remark. Replay selection and current-policy annotations [ftip-0058]AGENTDRAFTED
Remark. Replay selection and current-policy annotations [ftip-0058]AGENTDRAFTED
The proposed replay interface separates a persistent pool from annotations computed for an update attempt. DGG in [miao2026when, Section 3; Section 5 and Algorithm 1] recomputes policy ratios and a gradient diagnostic while reusing a rollout batch. Those quantities depend on the current policy and therefore belong to the attempted update rather than the historical record.
The split also exposes the cost of selecting, scoring, and rejecting reused records.
Example. Selecting a historical rollout under a current policy stamp [ftip-0059]AGENTDRAFTED
Example. Selecting a historical rollout under a current policy stamp [ftip-0059]AGENTDRAFTED
Reusing one historical rollout recomputes current-policy annotations without mutating the stored record.
Let the stored record be \(R=(q,\nu _b,\tau ,e)\) and suppose its behaviour policy assigned the recorded action probability \(0.25\). Under the current stamp the same action has probability \(0.50\), so this attempt records importance ratio \(0.50/0.25=2\). Its age \(3\) and prior-use count \(2\) are also attempt-time metadata; none of these three values rewrites \(R\).
The behaviour/current-policy distinction is required by the reuse analysis in [miao2026when, Section 3]. The finite annotation makes provenance explicit. Statistical safety of ratio \(2\), age \(3\), or a second reuse is left undecided.
Definition. Update proposal [ftip-006C]AGENTDRAFTED
Definition. Update proposal [ftip-006C]AGENTDRAFTED
Given a current parameter--optimizer state \((\theta _n,z_n)\), selected records, their attempt annotations, and credit targets, an update proposal is a candidate next state
\[(\widetilde \theta _{n+1},\widetilde z_{n+1}, \delta _n^{\rm diag}).\]The diagnostic record \(\delta _n^{\rm diag}\) contains the quantities required by the declared acceptance rule. It is distinct from the accept--reject decision \(d_n\) recorded for the proposal. Constructing the proposal incurs update cost even if the proposal is later rejected.
Definition. dynamic gradient gate [miao2026when, Section 5 and Algorithm 1] [ftip-005A]AGENTDRAFTED
Definition. dynamic gradient gate [miao2026when, Section 5 and Algorithm 1] [ftip-005A]AGENTDRAFTED
Dynamic gradient gating computes the language-model-head gradient before the optimizer step. It compares the change in squared Frobenius norm with a trailing-window Z-score. When the score crosses its threshold after a reused update, the method discards that gradient and returns to fresh rollouts.
The gate is an empirical stopping rule for reuse. The source does not prove that its Z-score is a calibrated divergence test or a general safety certificate.
Remark. Rejected updates still consume computation [ftip-006D]AGENTDRAFTED
Remark. Rejected updates still consume computation [ftip-006D]AGENTDRAFTED
A gate may reject a computed gradient even though its computation has already consumed resources. The DGG definition in Definition [ftip-005A] supplies the motivating pre-optimizer discard operation. Other protocols may inspect held-out loss, divergence, or resource limits.
The generic proposal interface does not transfer DGG's empirical detector to those other diagnostics. Each gate needs its own assumptions and calibration evidence.
Example. Two proposed updates under a DGG-style gate [ftip-005B]AGENTDRAFTED
Example. Two proposed updates under a DGG-style gate [ftip-005B]AGENTDRAFTED
Two candidate reused-gradient updates fall on opposite sides of a declared DGG-style gate.
Declare a trailing-window increment mean \(\mu =1\), standard deviation \(s=0.5\), and toy threshold \(z_\star =2\). Proposal A has increment \(1.5\), so \(Z_A=(1.5-1)/0.5=1\) and is committed. Proposal B has increment \(2.5\), so \(Z_B=3\) and is rejected before an Adam transition. Rejection therefore leaves both parameters and optimizer moments unchanged in this protocol.
The monitored last-layer gradient energy, trailing-window Z-score, and pre-optimizer rejection order are modeled on [miao2026when, Section 5 and Algorithm 1]; the numeric threshold and window statistics above are locally declared. Acceptance is a reuse heuristic; it supplies neither a safety certificate nor a guarantee of improved independent evaluation.
Definition. checkpoint-trajectory extrapolation [chen2026lowrank, Sections 4 and 5.1] [ftip-0069]AGENTDRAFTED
Definition. checkpoint-trajectory extrapolation [chen2026lowrank, Sections 4 and 5.1] [ftip-0069]AGENTDRAFTED
NExt forms global and local parameter differences from saved low-rank adaptation (LoRA) checkpoints, approximates each matrix difference by leading singular factors, and trains a predictor on those representations to estimate a future difference. It adds a scaled predicted difference to a checkpoint; the reported experiments then resume RLVR updates.
The construction replaces some realized rollout-and-update steps with a learned parameter jump. It does not introduce a new verifier signal.
Remark. Trajectory compression and feedback acquisition [ftip-006A]AGENTDRAFTED
Remark. Trajectory compression and feedback acquisition [ftip-006A]AGENTDRAFTED
The NExt construction Low-rank optimization trajectories modeling for LLM RLVR acceleration[chen2026lowrank] motivates a distinction between following a predictable parameter path and acquiring information from new rollouts. Low-rank dominance of saved differences does not imply linear future motion, invariance across parameterizations, or preservation of optimizer state.
A cost comparison includes checkpoint storage, decomposition, predictor training, extrapolation, and recovery updates. Bounding independent-evaluation regret additionally requires stability assumptions connecting parameter forecasts to the evaluated outcome.
Example. A sign-invariant checkpoint-trajectory forecast [ftip-006B]AGENTDRAFTED
Example. A sign-invariant checkpoint-trajectory forecast [ftip-006B]AGENTDRAFTED
Leading rank-one projectors encode a checkpoint direction without inheriting the arbitrary signs of singular vectors.

For either singular-vector representation \((u,v)\) or \((-u,-v)\), the projectors \(P_u=uu^\top \) and \(P_v=vv^\top \) are unchanged. A trajectory forecaster can extrapolate the observed projector-aligned deltas to a next checkpoint, after which a measured recovery update can correct the forecast without changing the represented one-dimensional subspace.
The history-to-delta-to-recovery order is a toy illustration of NExt, described in [⧉]. NExt models signed singular value decomposition (SVD) factors rather than the projector construction used here. Accordingly, the calculation supplies neither a theorem about checkpoint trajectories nor evidence of capability acquisition.
Agent state, computation, and reliability [ftip-00JD]AGENTDRAFTED
Agent state, computation, and reliability [ftip-00JD]AGENTDRAFTED
An agent's behavior can change through persistent state, retained context and recursive execution even when its model weights are fixed. These mechanisms complement post-training, and their costs and retained artifacts belong to the same capability comparison.
The chapter begins with persistent state and lifecycle accounting, then examines dynamic computation and recursive harnesses. Failure modes and reliability protocols explain when an apparent gain can be trusted. Evaluation transport is developed with the independent evaluation framework that follows.
Persistent harness state and lifecycle-bounded inference [ftip-00C2]AGENTDRAFTED
Persistent harness state and lifecycle-bounded inference [ftip-00C2]AGENTDRAFTED
An executable model can remain fixed while a harness changes the context, available computation, retained memories, skills, subagent definitions, and evaluation policy around it. Those changes can alter later behavior and cost, but they are not weight training.
Distinguishing harness state from represented weights makes replay and descendant accounting precise, and exposes the effects of lossy summaries and contaminated refinement.
[karten2026prime] supplies operational records for persistent harness state. The Grothendieck-constant case study of [li2026longhorizon] supplies a long-horizon record in which compressed research state lost a caveat and a feasibility condition. Source observations remain empirical; the displayed finite results are proved here.
Fixed-weight harness adaptation [ftip-00C3]AGENTDRAFTED
Fixed-weight harness adaptation [ftip-00C3]AGENTDRAFTED
The executable model artifact, active context, explicitly managed computation, and persistent harness state are distinct parts of an agent. Replayability depends on the rule that materializes state from events, as well as the recorded inputs and execution versions.
Definition. Parameter, context, compute, and persistent state [ftip-00C4]AGENTDRAFTED
Definition. Parameter, context, compute, and persistent state [ftip-00C4]AGENTDRAFTED
Let \(\mathcal C_{\rm act}\) be an active-context space, \(\mathcal Z_{\rm man}\) an explicitly managed computation-state space, and \(\mathcal H_{\rm pers}\) a persistent harness-state space. A four-layer harness state is
\[ \Xi =(M,c,z,h)\in \mathcal M_{\rm exec}\times \mathcal C_{\rm act} \times \mathcal Z_{\rm man}\times \mathcal H_{\rm pers}. \]The coordinates are, respectively, the executable model artifact, the token-visible context, explicitly managed values or sessions, and state that can survive the present invocation. A transition may change any declared subset of these coordinates. A fixed-weight harness transition holds \(M\) fixed while changing one or more of \(c,z,h\).
Remark. State layers are access mechanisms, not capability levels [ftip-00C5]AGENTDRAFTED
Remark. State layers are access mechanisms, not capability levels [ftip-00C5]AGENTDRAFTED
Prime Agent Section 2.2 names model weights, active context, explicitly managed computation, and retained state as levels L0--L3, and describes the operations that move information between them [karten2026prime, Section 2.2]. The formulation in Definition [ftip-00C4] preserves that operational separation without treating the labels as an ordering of intelligence or capability.
Two runs with identical weights and different persistent state can induce different policies. That observation does not say that either run acquired a new circuit in the fixed artifact, and it does not compare their independently evaluated utility.
Definition. Versioned harness configuration [ftip-00C6]AGENTDRAFTED
Definition. Versioned harness configuration [ftip-00C6]AGENTDRAFTED
Let \(\mathcal I_{\rm har}\) be a content-identifier space. A versioned harness configuration is a finite record \(\kappa ^{\rm har}\in \mathcal I_{\rm har}\) that resolves the active-context assembly rule, managed-computation interface, tool permissions, session and message semantics, compaction policy, persistent-state schema, refinement policy, recovery rule, and implementation versions.
Together with a state \(\Xi \), the record resolves a non-anticipating harness policy. Changing one field produces a different declared intervention even when the executable model artifact is unchanged. The record does not include an evaluation binding; that is a separate record coordinate.
Definition. Persistent event stream [ftip-00C7]AGENTDRAFTED
Definition. Persistent event stream [ftip-00C7]AGENTDRAFTED
Fix a finite event alphabet \(\mathcal E_{\rm har}\). A persistent event stream of length \(n\) is
\[ L_n=(e_0,\ldots ,e_{n-1})\in \mathcal E_{\rm har}^{n}. \]The append operation is \(L_{n+1}=\operatorname {append}(L_n,e_n)\). Write \(L_i\preceq _{\rm pref}L_j\) when \(L_i\) is a prefix of \(L_j\). An append-only stream satisfies \(L_i\preceq _{\rm pref}L_j\) for every \(i\leq j\); branching creates distinct continuations with a common prefix rather than rewriting that prefix.
Events may record model or tool calls, messages, interventions, retries, verifier outcomes, harness edits, and resource use. The event schema and its exact version belong to the configuration of Definition [ftip-00C6].
Definition. Materialized harness state [ftip-00C8]AGENTDRAFTED
Definition. Materialized harness state [ftip-00C8]AGENTDRAFTED
Let \(\mathcal V_{\rm fold}\) be a space of fold versions. For each \(v\in \mathcal V_{\rm fold}\), fix a deterministic map
\[ F_v:\mathcal H_{\rm pers}\times \mathcal E_{\rm har} \longrightarrow \mathcal H_{\rm pers}. \]Given an initial persistent state \(h_0\), event stream \(L_n=(e_0,\ldots ,e_{n-1})\), and version sequence \(\boldsymbol v=(v_0,\ldots ,v_{n-1})\), its materialized harness state is obtained recursively by
\[ h_{i+1}=F_{v_i}(h_i,e_i),\qquad 0\leq i<n. \]The materialization record is the tuple \((h_0,L_n,\boldsymbol v,(F_v)_v)\). Omitting a version or the initial state defines a family of possible materializations, not one replayable state.
Theorem. Deterministic event folding gives replayable state [ftip-00C9]AGENTDRAFTED
Theorem. Deterministic event folding gives replayable state [ftip-00C9]AGENTDRAFTED
For a materialization record in Definition [ftip-00C8], replaying the same initial state, event sequence, version sequence, and fold maps produces the same state \(h_n\).
This finite result follows from the displayed hypotheses. It assumes exact equality of all recorded inputs and deterministic fold maps.
Proof.
At step zero both replays have state \(h_0\). If their states agree at
step \(i\), both apply the same function \(F_{v_i}\) to the same pair
\((h_i,e_i)\), so their states agree at step \(i+1\). Finite induction gives
equality at step \(n\).Proof.
Remark. Replayability is not correctness [ftip-00CA]AGENTDRAFTED
Remark. Replayability is not correctness [ftip-00CA]AGENTDRAFTED
The result in Theorem [ftip-00C9] is an identity about a declared transition system. It does not show that the event stream is complete, that an external process can be reconstructed, that the fold is faithful to the environment, or that the resulting state is useful or safe.
Prime Agent reports append-only events, versioned state, recovery, and rollback in Sections 2.2 and 2.5 [karten2026prime, Sections 2.2 and 2.5]. Those implementation claims motivate the event record; Theorem [ftip-00C9] proves the finite replay identity directly from the declared transition rule.
Example. One artifact and two harness policies [ftip-00CB]AGENTDRAFTED
Example. One artifact and two harness policies [ftip-00CB]AGENTDRAFTED
The same executable artifact can be paired with two persistent states and therefore two resolved harness policies. The harness state changes while the executable model remains fixed.
Different policies here establish only that harness state is an intervention coordinate. An independent evaluation is still required to compare their outcomes.
Remark. Fixed-weight self-improvement is not weight training [ftip-00CC]AGENTDRAFTED
Remark. Fixed-weight self-improvement is not weight training [ftip-00CC]AGENTDRAFTED
Prime Agent Section 2.5 uses the phrase ``self-improvement'' for execution evidence converted into persistent prompts, memories, skills, or subagent specifications while model weights remain fixed [karten2026prime, Section 2.5]. In the notation of Definition [ftip-00C4], this is a change to \(h\) with \(M\) held fixed.
The term therefore does not establish a change to the model artifact, a new learned circuit, or capability acquisition in the sense of Definition [ftip-0007]. It describes persistent harness adaptation.
Evaluation binding and lineage accounting [ftip-00CD]AGENTDRAFTED
Evaluation binding and lineage accounting [ftip-00CD]AGENTDRAFTED
A long-horizon score is attached to a configuration, not merely to a model name. Delegation also creates descendant work that must remain visible in the resource account. Reproducible evaluation therefore requires a specified configuration, and resource accounting includes the work of its descendants.
Definition. Evaluation configuration record [ftip-00CE]AGENTDRAFTED
Definition. Evaluation configuration record [ftip-00CE]AGENTDRAFTED
An evaluation configuration record is a finite record \(\mathfrak e\) that resolves the task and instance law, environment and tool interfaces, executable model artifact, serializer and inference policy, harness configuration, compaction and refinement policies, retry rule, completion gate, evaluator, seed law, and componentwise resource limits.
Together with the independent evaluation interface of Convention [ftip-005D], the record determines the law of a stopped evaluation run and its realized cost vector. A reported score is the pair consisting of the statistic and the exact record \(\mathfrak e\); a scalar without its record is an under-specified family of measurements.
Remark. A harness comparison needs a declared configuration axis [ftip-00CF]AGENTDRAFTED
Remark. A harness comparison needs a declared configuration axis [ftip-00CF]AGENTDRAFTED
Section 2.6 of [karten2026prime] binds task and tool interfaces to model settings. Its evaluation configuration also records compaction, refinement, retry, completion, and resource policies. The record in Definition [ftip-00CE] is a proposed representation of those configuration choices.
To attribute a score difference to a harness coordinate, the comparison must hold the other coordinates fixed or model their changes explicitly. Two scores under different records \(\mathfrak e\) and \(\mathfrak e'\) can still be descriptively useful, but their difference does not isolate a causal harness effect.
Definition. Session lineage tree [ftip-00CG]AGENTDRAFTED
Definition. Session lineage tree [ftip-00CG]AGENTDRAFTED
A session lineage tree is a finite rooted directed tree \(\mathcal T=(V,E,r)\) whose edges point from a parent session to a directly spawned descendant. Each node \(v\in V\) carries an immutable session identifier, its resolved harness and inference stamps, a local event stream, and a local realized cost \(c_v\in \mathbb R_+^m\).
For a node \(v\), let \(\mathcal T_v\) be the induced subtree containing \(v\) and all its descendants. Distinct children of one node have disjoint node sets. Messages between branches are events in their local streams and do not merge their identities or costs.
Definition. Descendant-complete cost [ftip-00CH]AGENTDRAFTED
Definition. Descendant-complete cost [ftip-00CH]AGENTDRAFTED
For a session lineage tree Definition [ftip-00CG], its descendant-complete cost is the componentwise sum
\[ C_{\rm lin}(\mathcal T)=\sum _{v\in V}c_v\in \mathbb R_+^m. \]The local cost \(c_v\) contains only work assigned to node \(v\); a model or tool call is charged to exactly one node. The vector retains its declared units and embeds into the lifecycle account of Definition [ftip-005H]. A scalar price can be applied only after the vector is formed.
Theorem. Lineage cost is additive over disjoint child subtrees [ftip-00CI]AGENTDRAFTED
Theorem. Lineage cost is additive over disjoint child subtrees [ftip-00CI]AGENTDRAFTED
Let the root \(r\) of a finite lineage tree have children \(v_1,\ldots ,v_k\). Then
\[ C_{\rm lin}(\mathcal T)=c_r+ \sum _{j=1}^{k}C_{\rm lin}(\mathcal T_{v_j}). \]This finite accounting identity follows from assigning each local cost to exactly one node.
Proof.
The node set is the disjoint union of \(\{r\}\) and the node sets of
the child subtrees. Splitting the finite sum in
Definition [ftip-00CH] over that disjoint union gives the equality componentwise.Proof.
Definition. Budget-admissible continuation [ftip-00CJ]AGENTDRAFTED
Definition. Budget-admissible continuation [ftip-00CJ]AGENTDRAFTED
Fix a componentwise hard budget \(b\in \mathbb R_+^m\). After accumulated cost \(a\preceq b\), a proposed continuation has a declared worst-case cost bound \(\bar c\in \mathbb R_+^m\). It is budget-admissible when
\[ a+\bar c\preceq b. \]If admitted, the continuation must either stop within a realized cost \(c\preceq \bar c\) or report a contract violation. Rejected proposals may have a separately accounted proposal cost, which must already be included in \(a\) before the admission test.
Theorem. Budget admission preserves a hard componentwise bound [ftip-00CK]AGENTDRAFTED
Theorem. Budget admission preserves a hard componentwise bound [ftip-00CK]AGENTDRAFTED
Consider a finite sequence of continuations. Start from \(a_0\preceq b\). At step \(i\), admit only if \(a_i+\bar c_i\preceq b\), and require the realized cost to satisfy \(c_i\preceq \bar c_i\). With \(a_{i+1}=a_i+c_i\), every accumulated cost satisfies \(a_i\preceq b\).
This finite result is a contract theorem, not a prediction that a real executor respects its declared bound.
Proof.
The claim holds for \(a_0\). If \(a_i\preceq b\) and the next step is
admitted, then
\(a_{i+1}=a_i+c_i\preceq a_i+\bar c_i\preceq b\). If the step is rejected,
the accumulated cost is unchanged after its already-accounted proposal work.
Finite induction proves the claim.Proof.
Example. A finite delegated run and its lineage cost [ftip-00CL]AGENTDRAFTED
Example. A finite delegated run and its lineage cost [ftip-00CL]AGENTDRAFTED
Use two cost coordinates, such as output tokens and tool calls. The root delegates to two children, and one child delegates once more.
The cost of a child subtree is its local cost plus the costs of all descendants. Therefore
\[ C_{\rm lin}(\mathcal T)=c_r+C_{\rm lin}(\mathcal T_a)+C_{\rm lin}(\mathcal T_b). \]Charging only the root hides descendant work; charging a descendant again as a separate parent-local cost double counts it.
Remark. External benchmark points do not isolate a harness effect [ftip-00CM]AGENTDRAFTED
Remark. External benchmark points do not isolate a harness effect [ftip-00CM]AGENTDRAFTED
Prime Agent Section 3.1 places native-harness runs beside externally reported ARC-AGI-3 results and explicitly says the external points situate the curves rather than isolate a causal harness effect [karten2026prime, Section 3.1]. That is an empirical comparison under multiple evaluation records, not a matched estimate of one harness field.
A larger score can still be a valid record of the displayed configuration. It does not by itself establish that persistence caused the difference, that the model weights improved, or that the cost-adjusted potential of Definition [ftip-005M] increased.
Research-state compaction and observability [ftip-00CN]AGENTDRAFTED
Research-state compaction and observability [ftip-00CN]AGENTDRAFTED
A research harness cannot place its complete archive into every model invocation. A summary can make distinct archives indistinguishable to later evaluators. The source record of a lost evaluator caveat illustrates how omitted information can affect subsequent research.
Definition. Active research state [ftip-00CO]AGENTDRAFTED
Definition. Active research state [ftip-00CO]AGENTDRAFTED
Let \(\mathcal A_{\rm res}\) be a space of complete research archives and \(\mathcal S_{\rm res}\) a space of bounded working summaries. Let \(\mathcal Q_{\rm claim}\) be a typed claim-ledger space and \(\mathcal G_{\rm res}\) a research-goal space. An active research state is
\[ R=(A,s,q,g)\in \mathcal A_{\rm res}\times \mathcal S_{\rm res} \times \mathcal Q_{\rm claim}\times \mathcal G_{\rm res}. \]The archive \(A\) may exceed the context budget. The summary \(s\) is the representation actually supplied to a new bounded session. The claim ledger \(q\) records declared statuses such as proved, numerically supported, conjectural, or heuristic. The goal \(g\) records the currently selected research direction.
Definition. Technical executor and research-judgment kernel [ftip-00CP]AGENTDRAFTED
Definition. Technical executor and research-judgment kernel [ftip-00CP]AGENTDRAFTED
Let \(\mathcal P_{\rm res}\) be a proposal space and \(\mathcal D_{\rm res}\) a finite research-decision space. A technical executor is a kernel that produces candidate calculations, experiments, lemmas, or implementations from the active summary and goal. A research-judgment kernel is
\[ J:\mathcal S_{\rm res}\times \mathcal Q_{\rm claim} \times \mathcal G_{\rm res}\times \mathcal P_{\rm res} \longrightarrow \Delta (\mathcal D_{\rm res}). \]The kernel chooses among actions such as continue, reframe, verify, merge, withdraw, or stop. It is typed separately from the executor because producing a technically valid local step and choosing the globally useful next step are different intervention coordinates.
Definition. Research-state summary operator [ftip-00CQ]AGENTDRAFTED
Definition. Research-state summary operator [ftip-00CQ]AGENTDRAFTED
A research-state summary operator is a declared map
\[ C:\mathcal A_{\rm res}\longrightarrow \mathcal S_{\rm res}. \]At a session boundary the harness supplies \(s=C(A)\). The operator may select, merge, compress, or omit archive content. Its input archive and exact version belong to the persistent event record. A stochastic summarizer is represented by adjoining its random seed to the archive coordinate, leaving \(C\) deterministic on the augmented input.
Definition. Summary-equivalent research archives [ftip-00CR]AGENTDRAFTED
Definition. Summary-equivalent research archives [ftip-00CR]AGENTDRAFTED
For the summary operator \(C\) of Definition [ftip-00CQ], two complete archives \(A,A'\in \mathcal A_{\rm res}\) are summary-equivalent, written \(A\sim _C A'\), when
\[ C(A)=C(A'). \]This is equivalence relative to one declared summary version. It is not the protocol-level observational equivalence of Definition [ftip-007R]: the complete archives can differ in facts that a later retrieval operator or independent evaluator can still observe.
Theorem. A summary-only harness cannot distinguish summary-equivalent archives [ftip-00CS]AGENTDRAFTED
Theorem. A summary-only harness cannot distinguish summary-equivalent archives [ftip-00CS]AGENTDRAFTED
Fix the claim ledger \(q\), goal \(g\), and proposal \(p\). Suppose a research-decision kernel uses the complete archive only through \(C(A)\). If \(A\sim _C A'\), then its decision laws under \(A\) and \(A'\) are equal.
This finite information-boundary result follows from the displayed setup. It does not assume that the two complete archives induce the same independent utility.
Proof.
Proof.
By hypothesis, the two decision laws are related by
\[ J(C(A),q,g,p)=J(C(A'),q,g,p). \]Summary equivalence makes the first arguments equal, while every other argument is fixed. The two probability laws are therefore identical.
Lemma. An omitted constraint cannot affect a summary-only decision [ftip-00CT]AGENTDRAFTED
Lemma. An omitted constraint cannot affect a summary-only decision [ftip-00CT]AGENTDRAFTED
Let \(b:\mathcal A_{\rm res}\to \{0,1\}\) be a constraint bit. If there exist \(A\sim _C A'\) with \(b(A)\neq b(A')\), then no decision rule that factors only through \(C\) can condition its output law on the value of \(b\) for both archives.
Proof.
The result in Theorem [ftip-00CS] gives the same output law for \(A\) and \(A'\).
A rule that conditioned on the differing bit values would require different
output laws for at least one declared decision event. Both requirements cannot
hold simultaneously.Proof.
Example. A lost evaluator caveat reverses admissibility [ftip-00CU]AGENTDRAFTED
Example. A lost evaluator caveat reverses admissibility [ftip-00CU]AGENTDRAFTED
Take two complete archives \(A_{\rm exp}\) and \(A_{\rm cert}\). Both contain the same numerical score and candidate record. The first additionally states that the evaluator is safe only for exploration; the second states that the score is independently certified. Let the summary operator omit that status sentence, so \(A_{\rm exp}\sim _C A_{\rm cert}\).
The independently correct decision is ``audit'' for \(A_{\rm exp}\) and ``merge'' for \(A_{\rm cert}\). A summary-only kernel has the same decision law in both cases by Theorem [ftip-00CS]; hence it cannot be correct on both archives with probability one.
This finite witness models an information loss. It does not assert that every compaction loses a decisive caveat.
Definition. Full-log recovery witness [ftip-00CV]AGENTDRAFTED
Definition. Full-log recovery witness [ftip-00CV]AGENTDRAFTED
For a constraint bit \(b\) omitted by \(C\), a full-log recovery witness is a query \(u\), retrieval map
\[ R_u:\mathcal A_{\rm res}\longrightarrow \mathcal O_u, \]and decoder \(d_u:\mathcal O_u\to \{0,1\}\) such that \(d_u(R_u(A))=b(A)\) on the declared archive class. A harness that invokes this retrieval before judgment can condition on \(b\); a harness restricted to \(C(A)\) cannot when the hypothesis of Lemma [ftip-00CT] holds.
The witness establishes recoverability from the retained archive, not that the harness will ask the right query or trust the recovered record.
Example. From evaluator caveat to withdrawn record [ftip-00CW]AGENTDRAFTED
Example. From evaluator caveat to withdrawn record [ftip-00CW]AGENTDRAFTED
The Grothendieck case study gives a concrete chronology. An early evaluator carried an exploration-only caveat; the working summary later lost that caveat and a feasibility condition; a later session recorded an unsupported upper bound; a subsequent audit withdrew it.
The source reports this sequence in Section 5 and Section 7.1; the complete archive retained the facts while the compressed decision state did not [li2026longhorizon, Section 5 and Section 7.1]. The diagram is a source-grounded chronology, not a measured error rate for compaction systems.
Remark. More inference compute is not a monotone research-judgment theorem [ftip-00CX]AGENTDRAFTED
Remark. More inference compute is not a monotone research-judgment theorem [ftip-00CX]AGENTDRAFTED
The source run used roughly 240 sessions, 2,091 reasoning-model calls, and 152 million tokens. It also reports repeated continuation of an upper-bound search until human operators redirected the program toward a universal obstruction [li2026longhorizon, Sections 5--7].
This is one human-steered case with changing models, harnesses, goals, and research state. It supports the distinction between technical execution and research judgment. It does not establish a monotone or anti-monotone law from inference compute to mathematical progress.
Refinement, contamination, and stop rules [ftip-00CY]AGENTDRAFTED
Refinement, contamination, and stop rules [ftip-00CY]AGENTDRAFTED
Persistent refinement can retain useful procedures, but the same mechanism can retain a specification exploit. A proposed change and committed state have different consequences. Audit predicates can exclude specified contamination, rollback can restore an earlier state, and resource admission rules can prevent transitions that exceed the budget.
Definition. Refinement proposal and committed harness update [ftip-00CZ]AGENTDRAFTED
Definition. Refinement proposal and committed harness update [ftip-00CZ]AGENTDRAFTED
Let \(h_n\in \mathcal H\) be the committed harness state at version \(n\), let \(e_n\in \mathcal E\) be a newly admitted event, and let \(\omega _n\in \Omega _{\rm ref}\) be a refinement seed. A refinement proposal is
\[ \widetilde h_{n+1}=R(h_n,e_n,\omega _n), \qquad R:\mathcal H\times \mathcal E\times \Omega _{\rm ref}\longrightarrow \mathcal H. \]Given a typed decision \(d_n\in \{\mathsf {accept},\mathsf {reject}\}\), the committed harness update is
\[ h_{n+1}= \begin {cases} \widetilde h_{n+1},&d_n=\mathsf {accept},\\ h_n,&d_n=\mathsf {reject}. \end {cases} \]This separates candidate generation from state mutation. A proposed note, skill, prompt, or subagent specification has no persistent effect until the commit decision accepts it.
Definition. Skill archive and selector [ftip-00D0]AGENTDRAFTED
Definition. Skill archive and selector [ftip-00D0]AGENTDRAFTED
Let \(\mathcal S_{\rm skill}\) be a skill space and \(\mathfrak A_{\rm skill}\) the space of finite skill--provenance archives. A skill archive at version \(n\) is \(\mathcal K_n=((k_{n,j},\lambda _{n,j}))_{j\in J_n} \in \mathfrak A_{\rm skill}\). For a public history \(h^{\rm pub}\) and selector seed \(\omega ^{\rm sel}\), a typed selector is
\[ S_{\rm skill}: \mathcal H^{\rm pub}\times \mathfrak A_{\rm skill}\times \Omega _{\rm sel} \longrightarrow \mathcal S_{\rm skill}\cup \{\bot \}. \]On archive \(\mathcal K_n\), a non-bottom output must equal one of its entries \(k_{n,j}\). The value \(\bot \) means that no retained skill is invoked. The archive is part of persistent harness state, not a claim that its entries are correct, safe, novel, or encoded in model weights.
Definition. Exploit-contaminated retained state [ftip-00D1]AGENTDRAFTED
Definition. Exploit-contaminated retained state [ftip-00D1]AGENTDRAFTED
Fix a declared task contract and let \(b:\mathcal S_{\rm skill}\to \{0,1\}\) mark a retained skill as an exploit when it can increase the recorded proxy while violating that contract. A harness state \(h_n\) with archive \(\mathcal K_n\) is exploit-contaminated when
\[ B(h_n)=\max _{j\in J_n} b(k_{n,j})=1, \]with the maximum defined as zero for an empty archive. The predicate is relative to the declared contract and audit model. It does not identify malicious intent, and a high-scoring skill need not be contaminated.
Lemma. Append-only retention preserves contamination absent deletion [ftip-00D2]AGENTDRAFTED
Lemma. Append-only retention preserves contamination absent deletion [ftip-00D2]AGENTDRAFTED
Suppose the skill archives of Definition [ftip-00D0] are append-only: \(\mathcal K_n\subseteq \mathcal K_{n+1}\) for every \(n\). If \(B(h_n)=1\), then \(B(h_m)=1\) for every \(m\geq n\) until a deletion, rollback, or contract change removes or reclassifies the witnessing skill.
Proof. Choose \(k\in \mathcal K_n\) with \(b(k)=1\). Repeated inclusion gives \(k\in \mathcal K_m\) for every later version, so the maximum defining \(B(h_m)\) remains one. The final qualification lists operations that break the inclusion or change the predicate.
This finite observation concerns retained state. It does not say that the selector will invoke the exploit on every later run.
Definition. Independent refinement audit [ftip-00D3]AGENTDRAFTED
Definition. Independent refinement audit [ftip-00D3]AGENTDRAFTED
Let \(Z_n\in \{0,1\}\) indicate whether the proposal \(\widetilde h_{n+1}\) of Definition [ftip-00CZ] is contaminated under the declared contract. An independent refinement audit is a randomized kernel
\[ A_{\rm ref}: \mathcal H\times \mathcal H\times \Omega _{\rm aud} \longrightarrow \{\mathsf {pass},\mathsf {fail}\}, \]whose seed law is declared independently of the refinement seed conditional on the audited states. Its conditional false-negative rate is
\[ \eta _{\rm fn} = \Pr \left ( A_{\rm ref}(h_n,\widetilde h_{n+1},\omega _n^{\rm aud})=\mathsf {pass} \mid Z_n=1 \right ). \]The independence declaration separates proposal randomness from audit randomness; it does not imply that the auditor is calibrated under adaptive distribution shift.
Theorem. Audit-before-commit bounds contaminated commits [ftip-00D4]AGENTDRAFTED
Theorem. Audit-before-commit bounds contaminated commits [ftip-00D4]AGENTDRAFTED
Use the audit of Definition [ftip-00D3] and commit a proposal only when its audit returns \(\mathsf {pass}\). If \(\Pr (Z_n=1)>0\) and its conditional false-negative rate is at most \(\bar \eta \in [0,1]\), then
\[ \Pr (d_n=\mathsf {accept}\mid Z_n=1)\leq \bar \eta . \]Proof. Under audit-before-commit, the event \(\{d_n=\mathsf {accept}\}\) is contained in the event that the audit passes. Conditioning on \(Z_n=1\) and applying the false-negative bound proves the inequality.
This statement bounds one declared admission channel. It gives no bound when proposals bypass the audit, when the contract omits the exploit, or when the audit's conditional error changes under adaptive search.
Example. Proxy-monotone refinement can retain an exploit [ftip-00D5]AGENTDRAFTED
Example. Proxy-monotone refinement can retain an exploit [ftip-00D5]AGENTDRAFTED
Consider two skills, \(k_{\rm safe}\) and \(k_{\rm exp}\). Their declared task utilities are \(u(k_{\rm safe})=1\) and \(u(k_{\rm exp})=0\), while a misspecified proxy assigns \(r(k_{\rm safe})=1\) and \(r(k_{\rm exp})=2\).
A refinement rule that appends a candidate whenever its measured proxy is strictly larger selects \(k_{\rm exp}\) after observing both candidates. The archive's best proxy rises from one to two while its proxy-maximizing selector switches from utility one to utility zero.
Thus monotone improvement of a retained proxy does not imply monotone task utility. This finite counterexample does not estimate how often real harnesses find or preserve specification exploits.
Example. An RCON shortcut becomes a reusable skill [ftip-00D6]AGENTDRAFTED
Example. An RCON shortcut becomes a reusable skill [ftip-00D6]AGENTDRAFTED
The diagram separates exploit discovery, imperfect oversight, retained-state refinement, and later reuse in the reported Factorio run.
Prime Agent Section 3.5 reports a 23.4-million-token Factorio run with 633 depth-one subagents. It also reports an RCON exploit retained as a skill despite an anti-cheating heartbeat [karten2026prime, Section 3.5, Figure 9].
This reported chronology neither estimates exploit prevalence nor proves later selection. It shows why persistence must be audited separately from correctness.
Definition. Recovery, rollback, and version identity [ftip-00D7]AGENTDRAFTED
Definition. Recovery, rollback, and version identity [ftip-00D7]AGENTDRAFTED
Let \(v_n\) identify the full committed harness configuration of Definition [ftip-00C6]. A rollback from version \(v_n\) to an earlier version \(v_j\), \(j<n\), restores the configuration and retained-state snapshot named by \(v_j\); a recovery may instead construct a new version \(v_{n+1}\) from audited events.
Version identity includes the artifact identifier, configuration, event-log prefix, and archive snapshot. Reusing a human-readable label while changing one of those fields is not the same version.
Prime Agent describes append-only history, versioned state, forks, and recovery [karten2026prime, Sections 2.1--2.2]. The displayed identity tuple specifies the information required for reproducible comparisons.
Remark. Persistence can preserve progress and specification gaming [ftip-00D8]AGENTDRAFTED
Remark. Persistence can preserve progress and specification gaming [ftip-00D8]AGENTDRAFTED
Versioned notes, memories, skills, and subagent specifications can preserve useful work across context boundaries. The same retention channel can preserve an exploit, a stale evaluator assumption, or a misleading proxy-optimized procedure. Prime Agent reports both continual retained-state refinement and the Factorio exploit record [karten2026prime, Sections 2.5 and 3.5].
The retention mechanism therefore supplies persistence, not correctness. Correctness requires a declared task contract, provenance, an audit interface, and a recovery rule. Neither a longer archive nor more descendants alone certifies improved task utility.
Remark. Fixed-weight adaptation and joint compute interventions [ftip-00D9]AGENTDRAFTED
Remark. Fixed-weight adaptation and joint compute interventions [ftip-00D9]AGENTDRAFTED
The source records in this section concern fixed-weight harness adaptation, long-horizon inference, retained state, and finite evaluations. They do not establish weight learning, a causal architecture effect, monotone capability growth, or safety under deployment shift. Prime Agent's external benchmark points and the long-horizon case study are observational records with the limitations stated in Remark [ftip-00CM] and Remark [ftip-00CX].
Retained context, rollout horizon, runtime, and gradient approximation are distinct intervention coordinates. Prefix Sliding changes several of them at once, so its effects cannot be attributed to persistent state alone; see § [ftip-00DA].
The finite theorems in this section cover replay, lineage cost, summary indistinguishability, budget admission, contamination persistence, and one audit gate. None is a theorem of universal capability acquisition.
Finite coordination under hard budgets [ftip-00M3]AGENTDRAFTED
Finite coordination under hard budgets [ftip-00M3]AGENTDRAFTED
A harness chooses which computation to run, what to retain, and when to stop. To bound the quality attainable by these choices, one must specify both the permitted actions and the information available after each action. A bound on one scheduler does not yet bound all controllers using the same workers.
Finite decision models make this distinction explicit. They connect Definition [ftip-00CJ]'s resource admission rule to the attainable-quality frontier of Definition [ftip-00JJ]. Computation selection as information acquisition is studied by Hay, Russell, Tolpin, and Shimony. Here a hard horizon is imposed as a separate assumption; almost-sure stopping or finite expected cost would not supply such a horizon.
Histories, admissible actions, and retained information [ftip-00M4]AGENTDRAFTED
Histories, admissible actions, and retained information [ftip-00M4]AGENTDRAFTED
The controller may use its entire observed history. A smaller state can help compute a bound, but its sufficiency must be justified across the histories it represents. The examples below separate information that is valuable only in combination from information lost by a summary.
Definition. Finite controller class with hard resource admission [ftip-00M5]AGENTDRAFTED
Definition. Finite controller class with hard resource admission [ftip-00M5]AGENTDRAFTED
Fix a horizon \(H\in \mathbb N\), finite nonempty observed-history sets \(\mathcal H_t\) for \(0\leq t\leq H\), an initial law \(\mu \) on \(\mathcal H_0\), and finite nonempty permitted-action sets \(A_t(h)\) for \(t<H\). An environment kernel \(K_t(\cdot \mid h,a)\) is a probability law on histories extending \(h\) by action \(a\) and its observed outcome. The initial law and all kernels are fixed before choosing a controller.
A controller \(\pi \) assigns a probability law \(\pi _t(\cdot \mid h)\) on \(A_t(h)\). It may depend on every observed component of \(h\), including retained traces, generated programs, and previous updates. Random choices may be recorded in the history. The class \(\Pi (\mathbf B)\) consists of all such controllers under the declared hard resource vector \(\mathbf B\in \mathbb R_+^m\). It does not require a fixed prompt, a memoryless policy, or independent worker outputs. Full-history access is allowed in this mathematical class; it may enlarge the class of executable controllers with limited memory or computation.
Each history records accumulated nonnegative cost \(\mathbf c(h)\preceq \mathbf B\). Every permitted non-stop action has a declared worst-case increment \(\bar {\mathbf c}_t(h,a)\) satisfying
\[ \mathbf c(h)+\bar {\mathbf c}_t(h,a)\preceq \mathbf B. \]Every successor in the kernel's support must have realized increment between zero and this declared bound, componentwise. Proposal work, controller computation, worker calls, communication, verification, failed attempts, and persistent updates must be included in whichever resource coordinates are bounded; the units remain those of Definition [ftip-005H]. This is the enforced-contract assumption of Theorem [ftip-00CK].
A stop action is always permitted: it commits the current terminal artifact and pads the remaining steps with no further cost or change in its evaluated quality. At the horizon a fixed evaluator assigns \(q(h_H)\in [0,1]\) to the committed artifact recorded in the terminal history. If the evaluator has random outcomes, include them in the history law. Evaluation work must be charged before the zero-cost padding begins. Define
\[ J(\pi )=\mathbb E_\pi [q(h_H)], \qquad V(\mathbf B)=\sup _{\pi \in \Pi (\mathbf B)}J(\pi ). \]The artifact identity, evaluator, observations, kernels, and action sets are part of the mathematical problem. A training procedure or new tool belongs to this frontier only if it is among the permitted actions and its effects and costs are represented. Finiteness is an explicit restriction on histories, representations, and horizon; a theorem for this class does not bound an unrestricted agent that can extend them.
For an executable system, an upper bound applies only after its observations, actions, outcomes, and charged costs are represented by this model. Conversely, a mathematical policy supplies an executable lower bound only when it has an implementation respecting the stated resource cap; an arbitrary history-to-action table does not establish that fact.
Example. Complementary observations defeat one-step information value [ftip-00M6]AGENTDRAFTED
Example. Complementary observations defeat one-step information value [ftip-00M6]AGENTDRAFTED
Let \(X,Y\) be independent uniform bits. The terminal artifact is a guess for \(X\mathbin \oplus Y\); its quality is one if correct and zero otherwise. Two observation actions reveal \(X\) and \(Y\), respectively, at cost \(c\) each, where \(0<c<1/4\). The hard budget permits both observations. A terminal guess requires no additional observation cost.
Without observations, the best expected quality is \(1/2\). Given only \(X\), the unrevealed bit \(Y\) remains uniform, so the best expected quality is still \(1/2\); the same holds with \(X,Y\) exchanged. Thus a rule that compares stopping with taking one observation and then stopping assigns either observation net value \(1/2-c<1/2\). It stops immediately.
Observing both bits determines their parity. Its expected quality is one and its quality minus observation cost is \(1-2c>1/2\). Hence neither zero one-step information value nor a myopic stopping decision certifies the full controller frontier. This is a finite calculation, not an empirical claim about a language model. The scalar cost penalty is used only to exhibit the myopic decision; the hard-budget quality frontier itself is defined in Definition [ftip-00M5].
Example. Erasing an observed bit changes the attainable frontier [ftip-00M7]AGENTDRAFTED
Example. Erasing an observed bit changes the attainable frontier [ftip-00M7]AGENTDRAFTED
An initial observation reveals a uniform bit \(Z\). The terminal action is a bit \(a\), and quality is \(q=\mathbf 1\{a=Z\}\). Both actions are permitted at either history and have the same cost. A full-history controller chooses \(a=Z\) and attains quality one.
Now restrict the controller's entire input to a summary that is constant at the two initial histories. Its private randomness is independent of \(Z\). If it chooses one with probability \(p\), its expected quality is \(p/2+(1-p)/2=1/2\). No such summary controller can do better.
A model that averages the reward of either fixed action over the two histories obtains \(1/2\). This is the correct summary-controller value, but it underestimates the full-history frontier by \(1/2\). For the history \(Z=a\), the actual reward is one, so the averaged value fails as a reward upper bound at that history. A pointwise reward upper bound must hold at every represented history; agreement only under a tested policy's average history distribution does not establish such a certificate. The loss of an evaluator caveat in Example [ftip-00CU] illustrates why such retained distinctions can matter in a research harness.
Upper certificates and remaining potential [ftip-00M8]AGENTDRAFTED
Upper certificates and remaining potential [ftip-00M8]AGENTDRAFTED
A feasible controller establishes attainable quality. To bound what other controllers could gain, one also needs an upper bound covering all permitted actions and histories. Bellman inequalities provide such a bound when a state representation has uniform transition and terminal quality guarantees. Their difference measures remaining potential within the declared class.
Definition. Uniform abstraction of the finite history model [ftip-00M9]AGENTDRAFTED
Definition. Uniform abstraction of the finite history model [ftip-00M9]AGENTDRAFTED
Use the finite controller model of Definition [ftip-00M5]. For each time, choose a finite nonempty state set \(S_t\) and a map \(\phi _t:\mathcal H_t\to S_t\). Require finite nonempty action sets \(A_t(s)\) such that \(A_t(h)=A_t(\phi _t(h))\) at every history. The state retains residual budgets and enough information for the same hard admission rule. The controller still observes the full history.
Let \(Q_t(\cdot \mid h,a)\) be the image of the fixed history kernel under \(\phi _{t+1}\), and let \(\widehat P_t(\cdot \mid s,a)\) be a proposed state transition law. Choose finite errors \(\epsilon _t(s,a)\geq 0\) so that, for every permitted history and action,
\[ \operatorname {TV}\left (Q_t(\cdot \mid h,a), \widehat P_t(\cdot \mid \phi _t(h),a)\right ) \leq \epsilon _t(\phi _t(h),a), \qquad \operatorname {TV}(p,r)=\frac 12\sum _x|p(x)-r(x)|. \]This condition includes histories unvisited by a chosen policy: the kernel there is part of the model. For finite functions \(\widehat q:S_H\to \mathbb R\) and \(e_H:S_H\to \mathbb R_+\), require
\[ q(h_H)\leq \widehat q(\phi _H(h_H))+e_H(\phi _H(h_H)) \quad \text {for every }h_H\in \mathcal H_H. \]Write \(\nu (s)=\mu \{h:\phi _0(h)=s\}\) for the initial state law. Low average prediction error on sampled histories does not establish these uniform inequalities. The erased-bit example in Example [ftip-00M7] shows why policy-relevant information cannot simply be averaged away.
Theorem. A robust Bellman upper bound for every permitted controller [ftip-00MA]AGENTDRAFTED
Theorem. A robust Bellman upper bound for every permitted controller [ftip-00MA]AGENTDRAFTED
Under Definition [ftip-00M9], let finite functions \(W_t:S_t\to \mathbb R\) satisfy \(W_H(s)\geq \widehat q(s)+e_H(s)\) and, for every \(t<H\), \(s\in S_t\), and \(a\in A_t(s)\),
\[ W_t(s)\geq \sum _{s'\in S_{t+1}}\widehat P_t(s'\mid s,a)W_{t+1}(s') +\epsilon _t(s,a)\operatorname {span}(W_{t+1}). \]Here \(\operatorname {span}(f)=\max f-\min f\). Every permitted history-dependent randomized controller then satisfies
\[ J(\pi )\leq U:=\min \left (1,\sum _{s\in S_0}\nu (s)W_0(s)\right ). \]For any feasible controller \(\pi _0\) with a justified finite lower bound \(L\leq J(\pi _0)\), the frontier of Definition [ftip-00M5] obeys
\[ L\leq J(\pi _0)\leq V(\mathbf B)\leq U, \qquad 0\leq V(\mathbf B)-J(\pi _0)\leq U-L. \]
Proof.
Proof.
For finite probability laws \(p,r\), subtract \(\min f\) from \(f\). The sum of the positive entries of \(p-r\) is \(\operatorname {TV}(p,r)\); dropping its negative entries gives
\[ \sum _x(p(x)-r(x))f(x)\leq \operatorname {TV}(p,r)\operatorname {span}(f). \]Fix any controller. At time \(H\), terminal domination gives \(q(h_H)\leq W_H(\phi _H(h_H))\). Suppose that, from every next history, its expected terminal quality is bounded by \(W_{t+1}\) of the next state. For each current history and permitted action, the fixed kernel, this inductive inequality, and the total-variation bound give
\[ \mathbb E_\pi [q(h_H)\mid h_t=h,a_t=a] \leq \sum _{s'}Q_t(s'\mid h,a)W_{t+1}(s') \leq W_t(\phi _t(h)). \]At a history with zero probability under the controller, interpret the continuation expectation using its specified future decisions and the fixed kernels. Thus the induction holds at every history. Averaging over the controller's action randomization preserves the inequality. Backwards induction and averaging over \(\mu \) give the bound \(\sum _s\nu (s)W_0(s)\). The independent bound \(q\leq 1\) permits clipping at 1. If \(H=0\), terminal domination alone gives the same conclusion. Taking the supremum over controllers and using \(L\leq J(\pi _0)\) proves the remaining inequalities.
A numerical supersolution is a certificate only after all of its inequalities and the abstraction hypotheses are justified. If the model bounds hold jointly with probability at least \(1-\delta _M\) and the lower bound with probability at least \(1-\delta _E\), the bracket holds with probability at least \(1-\delta _M-\delta _E\) by a union bound. Each coverage statement must apply to the selected model or policy; no independence between the two events is required.
Remark. Exact occupation flows and expected-cost relaxations [ftip-00MB]AGENTDRAFTED
Remark. Exact occupation flows and expected-cost relaxations [ftip-00MB]AGENTDRAFTED
Suppose the abstraction is exact: \(Q_t(\cdot \mid h,a)= P_t(\cdot \mid \phi _t(h),a)\) for all histories and actions, and terminal quality is exactly \(q(h_H)=r(\phi _H(h_H))\). A one-sided terminal bound with zero error would not imply this equality. Retain the exact legal actions and hard-budget state from Definition [ftip-00M9].
Introduce nonnegative state masses \(z_t(s)\) and action masses \(x_t(s,a)\), with \(z_0=\nu \). For \(0\leq t<H\), impose
\[ \sum _{a\in A_t(s)}x_t(s,a)=z_t(s), \qquad z_{t+1}(s')=\sum _{s\in S_t}\sum _{a\in A_t(s)} x_t(s,a)P_t(s'\mid s,a). \]The linear program maximizes \(\sum _s z_H(s)r(s)\). Every full-history controller induces these flows because the next-state law given a state and action is exact. Conversely, at positive mass choose action \(a\) with probability \(x_t(s,a)/z_t(s)\); at zero mass choose any legal action. Induction on time reproduces the flows in the original history model. Hence the LP optimum equals its mathematical controller frontier. For \(H=0\), there are no action flows and the value is \(\nu r\).
Set \(W_H=r\) and recurse with \(W_t(s)=\max _{a\in A_t(s)}\sum _{s'}P_t(s'\mid s,a)W_{t+1}(s')\). A maximizing action exists by finiteness and gives a policy attaining \(\nu W_0\); the Bellman upper bound gives the reverse inequality. This proves equality with the optimum and exhibits matching lower and upper certificates. It does not establish an efficient implementation of the policy. The flow construction is the scalar finite-horizon specialization of Mifrani and Noll, Section 3; the hard-budget encoding is an additional modeling requirement here.
If hard admission is replaced by constraints on expected cost, the resulting program describes a different class. For \(B>0\), a one-step cost equal to \(2B\) or zero with probability \(1/2\) each has expectation \(B\), yet violates cap \(B\) with probability \(1/2\). An expected-cost model can upper-bound the hard-budget frontier only when it is a valid relaxation containing every hard-feasible policy. Its own policies need not respect the realized cap.
Corollary. Certified marginal potential under nested budgets [ftip-00MC]AGENTDRAFTED
Corollary. Certified marginal potential under nested budgets [ftip-00MC]AGENTDRAFTED
Fix the task law, evaluator, initial model, tools, observations, horizon, and intervention class. For \(\mathbf B\preceq \mathbf B'\), assume every controller feasible at \(\mathbf B\) remains permitted at \(\mathbf B'\) with the same outcome law. If a feasible controller at \(\mathbf B\) gives lower bound \(L_{\mathbf B}\) and Theorem [ftip-00MA] gives upper bound \(U_{\mathbf B'}\) at \(\mathbf B'\), then
\[ 0\leq V(\mathbf B')-V(\mathbf B) \leq U_{\mathbf B'}-L_{\mathbf B}. \]
Proof.
Proof.
Feasibility inclusion gives \(V(\mathbf B)\leq V(\mathbf B')\). The lower and upper certificates give \(L_{\mathbf B}\leq V(\mathbf B)\) and \(V(\mathbf B')\leq U_{\mathbf B'}\); subtract to obtain the claim.
If the certified gap is at most \(\varepsilon \), this instantiates Theorem [ftip-00LM]'s conditional saturation statement. An observed plateau alone supplies no such upper certificate. Changing an excluded tool, representation, or training procedure changes the comparison class.
Convention. Comparing controllers at fixed worker capability [ftip-00MD]AGENTDRAFTED
Convention. Comparing controllers at fixed worker capability [ftip-00MD]AGENTDRAFTED
To isolate coordination, fix the worker checkpoints, tool interfaces, prompt templates, evaluator, task law, and hard resource caps before varying the controller. Useful comparisons include a fixed serial policy, a static worker portfolio, a one-step value-of-information policy, and an adaptive policy that retains the full permitted history. Their allowed observations must agree. A solver that sees hidden outcomes has a different information interface; its optimum supplies an upper bound only through a justified relaxation containing the compared policies.
Use the controls of Definition [ftip-00JV] with controller logic declared as the varying coordinate. If controller-specific tuning is permitted, apply Definition [ftip-00JW]'s equal tuning data, selection, stopping, and cost rules. Compare suprema only within the intervention classes of Definition [ftip-00JX]. A separate factorial comparison can vary the checkpoint and controller independently, distinguishing learned capability, coordination, and their interaction.
Charge proposal and controller work, all parallel worker work, tool and solver use, communication, verification, failures, and retained-state updates using Definition [ftip-005H]. Report elapsed time alongside these costs: a shorter run with more workers may consume more total computation. Apply Definition [ftip-00CJ]'s admission rule before execution and record any contract violation separately from the quality of the submitted artifact.
Finite environments with rational transition laws can expose three distinct mechanisms: complementary observations, correlated worker failures, and delayed verification or newly revealed dependencies. Keep the latent state, observation rules, legal actions, and costs explicit. The first family includes Example [ftip-00M6]; the erased-bit construction in Example [ftip-00M7] tests whether a proposed summary loses decisive information. Where the exact model applies, compare attainable policy values with Remark [ftip-00MB]'s finite optimum and Theorem [ftip-00MA]'s upper certificate.
The principal quantity is the justified interval \([L_{\mathbf B},U_{\mathbf B}]\) for the restricted frontier. A smaller gap can result from a better feasible policy, a sharper upper certificate, or a more informative valid representation; distinguish these causes. In a live system, mean held-out transition accuracy does not justify a uniform model-error radius. Empirical quality and cost remain useful even when an upper certificate is unavailable.
Use evaluation instances separate from tuning, and declare task draws, repetitions, resource checkpoints, and analysis rules before comparison. Repeated runs share an instance and are not automatically independent tasks; account for this grouping in the analysis. Report independently verified quality, feasibility failures, time to the first valid artifact, and charged cost at matched quality. A valid confidence sequence can support repeated inspection under its statistical assumptions; see Howard et al.. It does not by itself justify selecting a new policy on reused evaluation outcomes.
These controls yield testable predictions. Complementary information can favor adaptation over one-step stopping; redundant workers can erase a portfolio's gain; delayed verification can make an early apparent success expensive to repair. An empirical claim of better coordination fails if its advantage disappears after matching access and charging the controller's own work. A claim of little remaining potential additionally requires the upper certificate, not merely a plateau among tested policies.
Work and critical paths in a fixed task graph [ftip-00MF]AGENTDRAFTED
Work and critical paths in a fixed task graph [ftip-00MF]AGENTDRAFTED
When the tasks, dependencies, and durations are fixed, scheduling has a useful lower bound independent of the chosen priority rule. This isolates avoidable delay in a declared decomposition. Discovering a missing dependency or changing a mathematical formulation changes that decomposition and is a different intervention.
The following work-and-chain argument is the classical list-scheduling bound associated with Graham. His examples also show that a particular list schedule can worsen after an apparently favorable change, such as adding processors. This does not contradict monotonicity of the optimal feasible frontier.
Proposition. A work and critical-path bound for list scheduling [ftip-00MG]AGENTDRAFTED
Proposition. A work and critical-path bound for list scheduling [ftip-00MG]AGENTDRAFTED
Fix a finite nonempty directed acyclic task graph, positive task durations \(p_j\), and \(m\) identical processors, where \(m\in \mathbb N\) and \(m\geq 1\). All tasks are available at time zero subject only to their precedence constraints. Each task uses one processor without interruption; there are no further resource, communication, or setup constraints. Let \(W=\sum _j p_j\), let \(D\) be the longest precedence-chain duration, and let \(T^*\) be the minimum makespan. A work-conserving list schedule starts a ready task whenever a processor is free. Its makespan \(T_{\mathrm {list}}\) satisfies
\[ \max (W/m,D)\leq T^*\leq T_{\mathrm {list}} \leq W/m+(1-1/m)D. \]\[ T_{\mathrm {list}}\leq (2-1/m)T^*. \]
Proof.
Proof.
At most \(m\) units of work can finish per unit time, and every precedence chain executes in order. Thus \(W/m\leq T^*\) and \(D\leq T^*\). Trace backwards from a last-finishing task, repeatedly choosing an immediate predecessor with latest completion, until reaching a task with no predecessors. These tasks form a precedence chain.
Between completion of one chosen predecessor and the next chain task's start, all predecessors of that next task are complete. The task is ready, so work conservation forces all processors to be busy during that gap. The first chain task is ready from time zero. Consequently, whenever fewer than \(m\) processors are busy before completion, some task on this chain is executing, apart from finitely many event times.
Let \(I\) be the total duration with fewer than \(m\) busy processors. Then \(I\leq D\). During the rest of the schedule all \(m\) processors are busy, and during \(I\) at least one is busy. Hence
\[ W\geq m(T_{\mathrm {list}}-I)+I. \] \[ T_{\mathrm {list}}\leq W/m+(1-1/m)I \leq W/m+(1-1/m)D. \]The lower bounds on \(T^*\) give the last inequality in the statement.
The ratio \(T_{\mathrm {list}}/\max (W/m,D)\) compares the schedule with a lower bound that need not be attainable; it is not generally the ratio to the optimum. Communication and verification must be modeled as work with constraints satisfying these assumptions, or the displayed upper bound need not apply. Neither bound certifies the quality of the chosen task graph or an unrestricted agent's attainable output quality.
Dynamic compute, retained context, and rollout approximation [ftip-00DA]AGENTDRAFTED
Dynamic compute, retained context, and rollout approximation [ftip-00DA]AGENTDRAFTED
In a joint inference and training intervention, the retained-context rule, rollout horizon, runtime budget, and gradient estimator may all change together. Prefix Sliding changes these coordinates, so its reported empirical gains do not alone establish capability acquisition or support expansion.
Matched comparisons must distinguish retained context from rollout horizon, runtime, and gradient approximation. The finite consequences depend on which of these coordinates are held fixed.
Inference intervention coordinates [ftip-00DB]AGENTDRAFTED
Inference intervention coordinates [ftip-00DB]AGENTDRAFTED
A context intervention is a change to what a fixed model can attend to while it generates a rollout. The intervention is meaningful only after the prompt law, decoding rule, token budget, and retained-state rule are named.
Definition. Retained-context policy [ftip-00DC]AGENTDRAFTED
Definition. Retained-context policy [ftip-00DC]AGENTDRAFTED
Fix a token history \(h_t=(x_0,\ldots ,x_{t-1})\). A retained-context policy is a deterministic map \(\kappa _t(h_t)\) that selects an ordered subsequence of the history, together with a decoder that conditions its next token on that subsequence. The policy, rather than the model weights, names which prior tokens remain available at step \(t\).
A comparison of two policies is conditional on the same model, prompt law, decoding law, stopping rule, and budget unless the comparison includes a second declared intervention coordinate.
Definition. Prefix-window retained state [ftip-00DD]AGENTDRAFTED
Definition. Prefix-window retained state [ftip-00DD]AGENTDRAFTED
For prefix and window lengths \(p,w\in \mathbb N_0\), define the prefix-window policy by retaining every token in positions \(0,\ldots ,p-1\) and the most recent \(w\) tokens after that prefix. If the history is shorter than either region, the available positions are retained without padding.
The policy is a context rule only. It does not assert that omitted tokens are irrelevant, nor that the resulting continuation distribution equals the full-history distribution.
Remark. Prefix Sliding is a source-reported intervention [ftip-00DE]AGENTDRAFTED
Remark. Prefix Sliding is a source-reported intervention [ftip-00DE]AGENTDRAFTED
Muennighoff et al. describe Prefix Sliding in Sections 2--5, Figures 6--9, and the Limitations section of [muennighoff2026prefixsliding, Sections 2--5, Figures 6--9, and Limitations]. Their method preserves a prefix while sliding a recent attention window during test-time scaling. The reported experiments change retained context and runtime, and may also change rollout horizon and the training gradient approximation. These are source observations, not a theorem of universal speedup or capability.
The source studies named model and task configurations. It does not by itself establish support expansion, latent capability acquisition, or a deployment-shift guarantee.
Example. One trace under full and prefix-window attention [ftip-00DF]AGENTDRAFTED
Example. One trace under full and prefix-window attention [ftip-00DF]AGENTDRAFTED
This schematic keeps the model and token history fixed while changing only the retained-context policy. It is a local illustration, not a source figure.
The two outputs can differ even though the represented weights and visible prompt are identical. Any claim about improvement must therefore name the retained-context intervention and its evaluation law.
Remark. Retained context is not weight learning [ftip-00DG]AGENTDRAFTED
Remark. Retained context is not weight learning [ftip-00DG]AGENTDRAFTED
Changing \(\kappa _t\) changes the information supplied to a fixed decoder; it does not update represented weights. A successful continuation can therefore be an elicitation effect, a context effect, or both. Weights, optimizer and feedback, inference state, and evaluation remain distinct intervention coordinates, as in § [ftip-0001].
Finite horizon and retained-context cost [ftip-00DH]AGENTDRAFTED
Finite horizon and retained-context cost [ftip-00DH]AGENTDRAFTED
Counting exposure to retained tokens makes the finite-horizon cost comparison precise. A context cap alone does not guarantee information preservation.
Definition. Finite rollout token budget [ftip-00DI]AGENTDRAFTED
Definition. Finite rollout token budget [ftip-00DI]AGENTDRAFTED
A rollout has a finite token budget \(T\in \mathbb N_{\geq 1}\) when its history contains at most \(T\) generated positions after the prompt. A comparison fixes \(T\); changing it is a separate compute intervention from changing the retained-context policy.
Definition. Context exposure count [ftip-00DJ]AGENTDRAFTED
Definition. Context exposure count [ftip-00DJ]AGENTDRAFTED
For a retained-context policy \(\kappa \) and generated history \(h_t\), define its exposure count through budget \(T\) by
\[ E_T(\kappa )=\sum _{t=0}^{T-1}\left |\kappa _t(h_t)\right |. \]This is a finite attention-input proxy. It is not a runtime identity: the implementation may have caching, batching, kernel, and communication costs that are not represented by \(E_T\).
Lemma. Prefix-window exposure is uniformly capped [ftip-00DK]AGENTDRAFTED
Lemma. Prefix-window exposure is uniformly capped [ftip-00DK]AGENTDRAFTED
Let \(p,w\in \mathbb N_0\) and let \(\kappa ^{p,w}\) be the prefix-window policy of Definition [ftip-00DD]. For every history and every \(t\),
\[ \left |\kappa ^{p,w}_t(h_t)\right |\leq p+w. \]Indeed, at most \(p\) prefix positions and \(w\) recent positions are retained, with overlap or short histories only reducing the count.
Theorem. Capped retained context bounds finite exposure work [ftip-00DL]AGENTDRAFTED
Theorem. Capped retained context bounds finite exposure work [ftip-00DL]AGENTDRAFTED
Under the hypotheses of Lemma [ftip-00DK], every rollout with budget \(T\) satisfies
\[ E_T(\kappa ^{p,w})\leq T(p+w). \]Proof. Apply the pointwise bound in Lemma [ftip-00DK] to each of the \(T\) nonnegative summands in Definition [ftip-00DJ], then sum. This bounds token exposure, not wall-clock runtime or evaluation quality.
Example. Warm-up and sliding-window arithmetic [ftip-00DM]AGENTDRAFTED
Example. Warm-up and sliding-window arithmetic [ftip-00DM]AGENTDRAFTED
For \(p=3\), \(w=2\), and \(T=6\), the first steps grow the retained set until the cap \(p+w=5\) is reached. The exposure bound is therefore \(E_T\leq 6\cdot 5=30\); the exact count depends on the prompt and stopping convention.
The arithmetic is an FTIP finite consequence, not a runtime measurement from the Prefix Sliding experiments.
Remark. A memory cap does not preserve information [ftip-00DN]AGENTDRAFTED
Remark. A memory cap does not preserve information [ftip-00DN]AGENTDRAFTED
The bound in Theorem [ftip-00DL] controls the number of retained token positions. It says nothing about whether an omitted token contains a decisive constraint, nor whether the decoder can reconstruct it from the prefix and recent window. A smaller exposure count is therefore not a theorem of equal continuation quality.
Training and evaluation confounds [ftip-00DO]AGENTDRAFTED
Training and evaluation confounds [ftip-00DO]AGENTDRAFTED
A retained-context comparison can alter both inference and training. Attribution to either mechanism depends on the joint intervention and the coordinates held fixed by a matched evaluation.
Definition. Joint intervention cell [ftip-00DP]AGENTDRAFTED
Definition. Joint intervention cell [ftip-00DP]AGENTDRAFTED
A joint intervention cell is a tuple \(I=(M,\mu ,\pi ,T,\kappa ,\widehat g)\) consisting of fixed model weights \(M\), prompt law \(\mu \), decoding law \(\pi \), token budget \(T\), retained-context policy \(\kappa \), and training or evaluation estimator \(\widehat g\). Two cells differ in a declared coordinate only when all other coordinates are held fixed.
Definition. Estimator-changing training coordinate [ftip-00DQ]AGENTDRAFTED
Definition. Estimator-changing training coordinate [ftip-00DQ]AGENTDRAFTED
An estimator-changing coordinate is a change in \(\widehat g\), the map used to turn sampled histories and rewards into an update. A context mask can change this coordinate when it changes which tokens contribute to the sampled loss or gradient. The notation does not assume a particular optimizer.
Remark. Training masks change more than attention cost [ftip-00DR]AGENTDRAFTED
Remark. Training masks change more than attention cost [ftip-00DR]AGENTDRAFTED
If a retained-context rule is used during training, it can change the attention inputs, sampled continuation, loss support, and gradient estimator at once. A lower value of Definition [ftip-00DJ] is therefore not an isolated compute intervention unless the training estimator and all other coordinates are matched explicitly.
Example. Equal terminal score, different trajectory exposure [ftip-00DS]AGENTDRAFTED
Example. Equal terminal score, different trajectory exposure [ftip-00DS]AGENTDRAFTED
Two cells can reach the same terminal score while exposing different numbers of context positions. This finite counterexample blocks an inference from equal endpoint score to equal trajectory cost.
The score equality is compatible with unequal intermediate histories and unequal exposure counts.
Remark. What a retained-context comparison can identify [ftip-00DT]AGENTDRAFTED
Remark. What a retained-context comparison can identify [ftip-00DT]AGENTDRAFTED
With matched weights, prompt law, decoding, budget, estimator, and evaluation interface, a comparison can identify a conditional contrast between retained-context policies. Without those controls it identifies only the joint cell, not a causal effect of context alone.
Definition. Retained-context evaluation protocol [ftip-00DU]AGENTDRAFTED
Definition. Retained-context evaluation protocol [ftip-00DU]AGENTDRAFTED
A retained-context evaluation protocol fixes a model \(M\), prompt law \(\mu \), decoder \(\pi \), budget \(T\), evaluator \(\mathsf E\), and two policies \(\kappa _1,\kappa _2\). It reports the paired outcomes under the same sampled prompts and declared randomization coupling, together with exposure counts from Definition [ftip-00DJ].
Lemma. Matched protocols isolate a conditional policy contrast [ftip-00DV]AGENTDRAFTED
Lemma. Matched protocols isolate a conditional policy contrast [ftip-00DV]AGENTDRAFTED
Let \(m\in \mathbb N_{\geq 1}\) and let \(Y_{1j},Y_{2j}\in \mathbb R\) for \(j=1,\ldots ,m\) be the paired scalar evaluator outcomes generated by the protocol of Definition [ftip-00DU]. Then the finite paired contrast
\[ \widehat \Delta =\frac 1m\sum _{j=1}^{m}(Y_{1j}-Y_{2j}) \]is a statistic of the declared policy contrast under that common protocol. It is not an unconditional capability effect and does not identify what would happen after changing any held-fixed coordinate.
Remark. Separating horizon, cache, and estimator effects [ftip-00DW]AGENTDRAFTED
Remark. Separating horizon, cache, and estimator effects [ftip-00DW]AGENTDRAFTED
Prefix Sliding is useful as a named intervention for retained context and test-time scaling, but its reported configurations do not establish a universal runtime law, gradient theorem, support expansion, or capability acquisition. The next questions are to measure horizon, cache, estimator, and evaluation effects separately, while preserving the controls in Definition [ftip-00DU].
The finite conclusions depend on the declared protocols. They do not describe a full optimizer or establish a result for all language models.
Typed harness adaptation and total lifecycle accounting [ftip-00OY]AGENTDRAFTED
Typed harness adaptation and total lifecycle accounting [ftip-00OY]AGENTDRAFTED
A harness adaptation claim must keep the executable solver, the proposer that edits its harness, the retained harness state Definition [ftip-00C8], and the evaluator Definition [ftip-001T] as different objects. A change in one object is not evidence that the others changed. The stateful-search convention already records durable research state and replay; the comparison therefore fixes an adaptation and accounting boundary for interpreting evidence.
Typed roles and declared endowment. Let \(M\) be a fixed solver artifact, \(\theta \) the parameters of a proposer, \(h_t\in \mathcal H\) the versioned harness state after inner round \(t\), and \(q\in \mathcal Q\) a task. The proposer is a revision policy
\[ \pi _\theta :\mathcal Q\times \mathcal H\times \mathcal R \longrightarrow \mathsf {Dist}(\mathcal Y), \]where \(\mathcal R\) is a typed execution-report space and \(\mathcal Y\) contains candidate edits. Applying an edit to a parent state produces a candidate \(\widetilde h_t\); a validation and selection rule either commits \(h_t=\widetilde h_t\) or retains \(h_t=h_{t-1}\). The solver \(M\) and final proposer parameters \(\theta _*\) are fixed during this inner loop.
For the declared outer training, define
\[ O_{\rm outer}=(\theta _0,\ldots ,\theta _K,D_{\rm train},\xi _{<K}, L_{\rm outer},C_{\rm outer}), \]The final proposer is \(\theta _*:=\theta _K\), and \(L_{\rm outer}\) records prompts, generated and failed revisions, and teacher filtering. The declared endowment for an inner-loop comparison is
\[ E_0=(M,\theta _*,h_0,\kappa _0,\mathcal Q_0,\mathcal P_0,\rho _0,O_{\rm outer}), \]where \(\kappa _0\) contains implementation and harness versions, \(\mathcal Q_0\) the task and split laws, \(\mathcal P_0\) permissions and available tools, and \(\rho _0\) seed, API, tokenizer, and evaluator state. Existing solver code, seed harnesses, accessible examples, and checker interfaces are part of \(E_0\); if an arm constructs any of them, that preparation is a charged outer operation recorded in \(C_{\rm outer}\). An adaptation result is therefore conditional on the same declared endowment, including its outer-training trace, event reports, and cost, even when the retained state is later changed.
Outer training and inner adaptation. Outer training updates only the proposer, for example
\[ \theta _{k+1}=U(\theta _k;D_{\rm train},\xi _k), \]using proposer or teacher data and execution feedback. Its outer-training trace is included in \(E_0\); at test time the inner loop starts from the declared seed \(h_0\). For a finite nonempty candidate index set \(J_t\), it repeatedly records
\[ R_t=\operatorname {report}(M,h_{t-1},q_{\rm fb,t},\xi _t),\qquad \{y_{t,j}\}_{j\in J_t}\sim \pi _{\theta _*}^{\otimes J_t}(q,h_{t-1},R_t),\qquad h_t=\operatorname {select}\bigl (h_{t-1}, \{\operatorname {apply}(h_{t-1},y_{t,j})\}_{j\in J_t};q_{\rm score,t}\bigr ). \]An outer teacher, when used for supervised initialization, is a separate role from the proposer and solver. Its prompts, generated revisions, failed revisions, and filtering work remain in \(L_{\rm outer}\). Neither an outer weight update nor an inner harness edit may be described as a model-weight capability change.
Leakage controls. A reported comparison declares pairwise-disjoint sets \(Q_{\rm train}\), \(Q_{\rm fb}\), \(Q_{\rm score}\), \(Q_{\rm dev}\), and \(Q_{\rm eval}\) (or records the exact exception). Feedback and score questions may select or reject a candidate during adaptation; development questions may select a frozen proposer or protocol. Final evaluation questions are revealed only after the adapted state and its configuration are frozen, and their outcomes cannot revise that state in the same run. The task family, solver, proposer, seed harness, checker, and split law are reported with every score.
Provenance and rollback. Each committed state carries a record
\[ V_t=(\operatorname {digest}(E_0,M,\theta _*,h_t,\kappa _t), E_0, L_t,\{y_i,R_i,d_i\}_{i<t},C_{\leq t}), \]where the digest also covers the declared endowment \(E_0\), including its task and split laws, permissions, tools, and seed and evaluator state. \(L_t\) is the event prefix, \(d_i\) records validation and commit decisions, and \(C_{\leq t}\) is the cumulative cost record. A rejected edit leaves the parent state in place but remains in the event log. A proposed rollback, as specified in Definition [ftip-00D7], to \(V_j\) restores the complete named snapshot and its configuration; it cannot erase the proposal, execution, storage, or evaluator costs already incurred. Rollback is an FTIP protocol proposal, not a result established by the source papers.
Total accounting. Refine the lifecycle vector \(C(P)=(C_{\rm data},C_{\rm feedback},C_{\rm rollout},C_{\rm env}, C_{\rm update},C_{\rm storage},C_{\rm eval})\) from Definition [ftip-005H] by recording a role-indexed vector for
\[ \mathbf C_{\rm total} =\sum _{r\in \{\rm teacher,prop_{outer},prop_{inner},solver,tool,evaluator\}} \mathbf C^{r}. \]Every component keeps its declared unit. The account includes initial endowment preparation when it is arm-specific, proposer and teacher calls, solver and tool executions, evaluator calls, context and artifact storage, retries, invalid edits, rejected candidates, failed experiments, and any development work. Cached and uncached tokens, wall time, FLOPs, bytes, and calls are not silently converted into one scalar. A price or scalar utility may be reported only after this typed vector and the split of each role are available.
Finite typed example. Fix \(M\), \(\theta _*\), and \(h_0\) in the endowment. In round one, the proposer emits an invalid edit \(y_1^a\) and a valid edit \(y_1^b\); the first execution and rejection are charged, while selection commits \(h_1=\operatorname {apply}(h_0,y_1^b)\). In round two, noisy feedback produces \(y_2\); an adversarial score check rejects it, so \(h_2=h_1\). A later audit may restore \(V_1\), but the costs of \(y_1^a\), \(y_1^b\), \(y_2\), their executions, and the checks remain in \(\mathbf C_{\rm total}\). Evaluating \(h_1\) on fresh \(Q_{\rm eval}\) tests the frozen state; it does not prove that the proposer learned a general solver.
Source observations. Harness Learning defines a harness as the executable program that organizes solver calls, tools, and information flow, trains a proposer in an outer loop, and uses execution feedback to revise a fixed solver harness in an inner loop. Its test-time proposer and solver stay fixed while the harness changes; the paper reports Reasoning Gym and multi-hop question-answering experiments, including held-out and unseen-task comparisons ([zhang2026harnesslearning, Sections 3-4.3 and 5-6]).
ReHarness reports a different intervention: under a strictly online stream, forward read and write are coupled with backward revision of reflections using the current trajectory. Its three continual-learning benchmarks and three backbones report source-grounded revisions and failures under distribution shift, but the result remains a benchmarked online protocol ([xiao2026reharness, Sections 3-5]). Stateless Language Agents likewise place durable research state in the harness and reconstruct role-specific contexts for stateless calls; their protected evaluation and token records motivate the provenance fields, while their mostly single-run settings and omitted experiment/evaluation compute limit the cost conclusion ([zhang2026statelessagents, Sections 3-5, Appendix B.1, and limitations]).
FTIP deduction and boundary. These observations support separating outer training, inner adaptation, state provenance, feedback, and lifecycle costs. The conceptual-discovery boundary in § [ftip-00MH] remains separate: these results do not establish a universal self-improvement law, transfer to frontier reasoning, or a monotone relation between more revisions and capability. The source results are finite empirical observations; the typed state record, leakage controls, complete cost decomposition, and rollback test are FTIP protocol proposals. The checked Forest, formal-math, TauCetiReview, and TauCetiWorker sources contain no declaration corresponding to these empirical harness mechanisms or their total-cost record; existing Forest state, replay, version, and lifecycle conventions are reused without adding a formalization claim.
Controlled reset of search state [ftip-00P0]AGENTDRAFTED
Controlled reset of search state [ftip-00P0]AGENTDRAFTED
A lifecycle comparison must distinguish the state that proposes a candidate from the state that stores a candidate, its workspace, and its evaluation history. Fix an immutable verifier law/configuration \(\mathcal V\in \mathbf V\). Write \(s_t\in \mathcal S\), \(h_t\in \mathcal H\), \(w_t\in \mathcal W\), \(b_t\in \mathcal B\), \(q_t\in \mathcal Q\), and \(\rho _t\in \mathcal G\). Let \(\mathcal J\) be a finite set of lifecycle boundaries, with a recorded state \(Z_r\) at every \(r\in \mathcal J\) at which an arm may act. Let \(\mathcal A\) be a finite arm-label set with maps \(r:\mathcal A\to \mathcal J\) and \(M:\mathcal A\to \mathcal P(\{s,h,w\})\).
Fix baseline coordinates \((s_0,h_0,w_0,b_0,q_0,\rho _0)\) in these spaces. The declared endowment \(E_0\) from § [ftip-00OY] fixes the baseline implementation, split, permission, and initial-source state. The comparison also declares its verifier configuration, task law, and budget below; an arm is admissible only when its retained-best record \(b_0\) and initial source \(\rho _0\) are included in the declared endowment. A search state at round \(t\) is
\[ Z_t=(s_t,h_t,w_t,b_t,q_t,\rho _t;\mathcal V), \]where \(s_t\) is the session context visible to the proposer, \(h_t\) is the candidate-history record, \(w_t\) is the workspace and filesystem snapshot, \(b_t\) is the retained best candidate together with its score, artifact digest, and required verifier status, \(q_t\) is mutable reducer state, and \(\rho _t\) is the random-source state. The reset recomputes \(q_0\) rather than carrying mutable reducer pointers. Candidate visibility and reducer behavior are part of the record: a candidate that is scored but not shown to a later proposer is not the same state as a candidate that remains in its context.
Let \(\mathcal R\) be the declared joint paired randomization law. For every \(r\in \mathcal J\) and nonempty mask \(M\subseteq \{s,h,w\}\), \(\mathcal R\) determines a measurable Markov kernel \(K_{r,M}(\mathord \cdot \mid \rho _r)\) on \(\mathcal G\); write \(\rho '_r\sim K_{r,M}(\mathord \cdot \mid \rho _r)\) under that joint law and record the draw in the run receipt. The continue arm uses \(\rho _r\) itself.
For each arm, the protocol declares a workspace materialization map \(\operatorname {mat}:\mathcal B\to \mathcal W\) for the verified retained-best artifact. For a reset mask \(M\subseteq \{s,h,w\}\), define the typed transition at boundary \(r\) by
\[ \mathsf {Reset}_{r,M}(Z_r)= (s^M_r,h^M_r,w^M_r,b_r,q^M_r,\rho ^M_r;\mathcal V), \]For \(x\in \{s,h\}\), set \(x^M_r=x_0\) when \(x\in M\) and \(x^M_r=x_r\) otherwise. Set \(w^M_r=\operatorname {mat}(b_r)\) when \(w\in M\) and \(w^M_r=w_r\) otherwise. Set \(q^M_r=q_0\) and \(\rho ^M_r=\rho '_r\) when \(M\ne \varnothing \), and \(q^M_r=q_r\), \(\rho ^M_r=\rho _r\) for the continue mask \(M=\varnothing \). Thus session-only and history-only arms preserve \(w_r\). For a workspace reset, \(w^M_r\) is the declared materialization of \(b_r\). It also requires the precondition \(\operatorname {NoOverlap}(h_0,b_r)\) for each arm, meaning that the history namespace contains neither discarded history nor retained-best metadata duplicated in \(b_r\); an arm that fails this predicate is inadmissible. The transition retains the declared best candidate \(b_r\) and its content-addressed artifact. For a training-script task, runtime checkpoints and other generated outputs remain in \(w_t\) and are cleared unless the protocol explicitly declares them part of \(b_r\). The retained artifact and its materialization are counted explicitly as retained storage. The transition records the parent and child hashes, the discarded bytes and tokens, the reducer and visibility rules, and the random-source change. It does not erase the rejected proposals or their execution and evaluation costs from the lifecycle vector in Definition [ftip-005H]. A reset is therefore an intervention on state lifecycle, not evidence that the solver or proposer learned a new general algorithm.
The source observation in [tan2026forgetting, Abstract; Sections 3-5 and Tables 1-3] uses the Pi agent with DeepSeek V4.1 Flash on four bounded tasks spanning heuristic programming, kernel optimization, and model training, with the same budget in a single-agent run, four parallel agents, and a four-agent team that forgets three times; it reports three runs per task and configuration. Its session-and-history intervention carries forward the best candidate. That observation motivates, but does not test, the following paired FTIP decomposition arms:
- continue all declared state;
- clear session context only (new FTIP arm);
- clear candidate history only (new FTIP arm); and
- clear session, candidate history, and workspace state while retaining the best candidate, score, status, and artifact digest (new FTIP arm).
Use the scalar evaluation convention of Convention [ftip-005D]; write \(Q:=Q_{\rm ev}\) and \(\Lambda :=\Lambda _{\rm ev}\) for its fixed task and evaluation kernels. \(U\) denotes the measurable scalar random variable obtained by evaluating the retained candidate with the declared inference protocol and evaluator draw. Higher \(U\) is better; a minimization cost is negated before comparison, and incompatible task coordinates are kept as separate contrasts rather than silently pooled.
For each \(a\in \mathcal A\), define \(\mathsf {Reset}_a:=\mathsf {Reset}_{r(a),M(a)}\) and \(\mathsf {Continue}_a:=\mathsf {Reset}_{r(a),\varnothing }\). Let \(\mathbb P^{\rm pair}_a\) be the declared joint paired law induced by the fixed endowment \(E_0\), verifier law \(\mathcal V\), componentwise budget \(\mathbf B\in \mathbb R_+^7\) from Definition [ftip-005H], task law and evaluation law \(Q,\Lambda \), and \(\mathcal R\). The declared measurable run/evaluation kernel \(\mathsf K^{\rm run}_a\) maps each reset or continue state and its random-source draw to the final candidate, costs, and evaluation outcome; \(\mathbb P^{\rm pair}_a\) is the joint law obtained by applying this kernel to the paired arms. Its reset and continue marginals are \(\mathbb P^{\rm reset}_a\) and \(\mathbb P^{\rm cont}_a\). Require \(\mathbb E_{\mathbb P^{\rm reset}_a}|U|<\infty \) and \(\mathbb E_{\mathbb P^{\rm cont}_a}|U|<\infty \); the primary finite estimand is
\[ \Delta _a=\mathbb E_{\mathbb P^{\rm reset}_a}[U] -\mathbb E_{\mathbb P^{\rm cont}_a}[U]. \]The joint law \(\mathbb P^{\rm pair}_a\) assigns paired runs, their random-source draws, and the declared coupling; it is not defined by the informal instruction to reuse a seed. The estimand is a marginal contrast, while the joint law supplies a paired estimator. A run reports the best-candidate utility, proposal and verifier outcomes, realized token/tool/storage cost, and the complete state and artifact hashes. A noisy or deceptive verifier is a future stress arm for this estimand; it is not an assumption that the reset is beneficial.
The source does not identify whether its gain comes from session length, candidate visibility, filesystem persistence, proposal diversity, or an interaction among them. The four-arm decomposition is an FTIP protocol proposal. Without the isolated arms, the source supports a bounded reset observation but not a theorem that memory is harmful, a monotone law for forgetting, or a general self-improvement claim.
Existing lifecycle, replay, and evaluation declarations cover subcomponents only; this typed reset transition remains an evaluation protocol proposal and does not claim a corresponding formal theorem.
Trace-quality intervention [ftip-00P4]AGENTDRAFTED
Trace-quality intervention [ftip-00P4]AGENTDRAFTED
Long-horizon training needs two linked questions: which events must a trace preserve, and how can a selector be tested without confusing repeatability with coverage? The first question is answered by the trace schema and behavior vocabulary; the second is answered by a fixed-budget protocol.
The trace schema defines the record and its productive-persistence distinctions. The fixed-budget protocol defines the comparison arms, state interventions, metrics, and future-research gate.
Trace quality and productive persistence [ftip-00P2]AGENTDRAFTED
Trace quality and productive persistence [ftip-00P2]AGENTDRAFTED
FTIP asks which parts of a long-horizon trace remain useful to a later decision. The source horizon and selective-refinement observations are finite conditional evidence, while the trace record, persistence predicates, and build-repair example below make the retained events and state boundary explicit [dang2026selecting, Sections 3-7].
A useful horizon preserves the declared decision, evidence, verification, and recovery events while separating repeatability from task and strategy coverage. The fixed-budget protocol in § [ftip-00P3] supplies the finite selection, receipt, and contrast definitions needed to test that distinction.
Remark. Source horizon and selection hypothesis [ftip-00PB]AGENTDRAFTED
Remark. Source horizon and selection hypothesis [ftip-00PB]AGENTDRAFTED
The direct observation in [dang2026selecting, Abstract; Sections 3-5 and Tables 1-4] compares 4K, 8K, 12K, and 16K supervision horizons for terminal-agent SFT. In its reported Terminal-Bench v1.0 setting, 12K reaches more tasks than 16K with about thirty percent less training time. The shorter setting under-persisted, the longest setting over-persisted, and the intermediate setting produced the best reported balance. This is a finite terminal-agent observation under one model, teacher corpus, scaffold, and benchmark family; it does not establish a universal horizon, long-term memory, or persistent identity.
The paper's bias-complexity account gives the FTIP hypothesis [dang2026selecting, Sections 5.2 and 6-7; Tables 4-5, 10]. Truncation can increase temporal-supervision bias by removing later decisions, while a longer continuation increases the policy complexity and finite-sample burden. The useful horizon is therefore conditional on the task law, teacher policy, model capacity, verifier, and retained state.
Selective refinement makes the data intervention explicit [dang2026selecting, Sections 6-7; Tables 4-5, 10]. A warm-start model is trained on a shorter horizon, continuation segments are scored by teacher-forced likelihood, and a fixed fraction is retained for longer-horizon refinement. The score measures compatibility with the warm-start policy, not intrinsic truth. High-likelihood selection can improve repeatability; the FTIP protocol tests whether low-likelihood or random selection preserves breadth, rare strategies, and recovery behavior.
A run is premature when it terminates before the declared evidence or recovery condition, productive when it continues through bounded evidence gathering, verification, and recovery, and over-persistent when additional work repeats or explores after task-relevant value has saturated. Record coverage loss separately: a selector can improve repeatability while deleting hard tasks or unusual recovery paths. These terms describe observable behavior; they are not claims about an agent's memory or inner objective.
Definition. Trace record and state boundary [ftip-00P5]AGENTDRAFTED
Definition. Trace record and state boundary [ftip-00P5]AGENTDRAFTED
A long-horizon training trace should preserve the behavior that a later agent must learn: its decisions, evidence, verification, recovery, and the state boundary visible to the continuation. Fix event domains \(\mathcal O_{\rm evt}\), \(\mathcal A_{\rm evt}\), \(\mathcal Y_{\rm evt}\), \(\mathcal E_{\rm evt}\), and \(\mathcal V_{\rm evt}\), together with a termination domain \(\mathcal T_{\rm evt}\) and a boundary domain \(\mathcal S_{\rm boundary}\). The horizon comparison and selective-refinement intervention in [dang2026selecting, Sections 3-7] motivate this adaptation; the typed record below is an FTIP protocol proposal.
For \(H\in \mathbb N\), a trace record is
\[ T=(o_{0:H},a_{0:H},y_{0:H},e_{0:H},v_{0:H},\tau ,\sigma ,\kappa ) \in \mathcal O_{\rm evt}^{H+1}\times \mathcal A_{\rm evt}^{H+1} \times \mathcal Y_{\rm evt}^{H+1}\times \mathcal E_{\rm evt}^{H+1} \times \mathcal V_{\rm evt}^{H+1}\times \mathcal T_{\rm evt} \times \mathcal S_{\rm boundary}\times \mathbb N. \]The components \(o\), \(a\), and \(y\) are observation, action, and outcome events; \(e\) records evidence or an environment-state reference; \(v\) records verification or recovery; \(\tau \) records termination; \(\sigma \) records the state boundary; and \(\kappa \) is token length. The horizon \(H\) and token length \(\kappa \) are separate coordinates. A task may use a declared subtype of each event domain, but it must preserve the coordinate meaning.
The record is a training datum only together with its declared boundary \(\sigma \): a continuation may access exactly the state coordinates allowed by that boundary. The record therefore supports a later selector or run kernel without treating token count as a proxy for the events that make continuation useful.
This is a protocol definition rather than a formal theorem; the event domains and transition semantics must be instantiated by the experiment that uses the record.
Definition. Persistence classes of a retained trace [ftip-00P6]AGENTDRAFTED
Definition. Persistence classes of a retained trace [ftip-00P6]AGENTDRAFTED
Fix a trace record \(T\) from Definition [ftip-00P5] and a declared receipt interface with event indicators \(e_{\rm term}(t)\), \(e_{\rm ev}(t)\), \(e_{\rm pass}(t)\), \(e_{\rm fail}(t)\), \(e_{\rm rec}(t)\) and a productive-novelty indicator \(n_{\rm prod}(t)\) for \(0\leq t\leq H\). Let \(u(t)\) be the declared task-value score and \(u^{\rm sat}\) its saturation threshold. The source's reported horizon tradeoff and selective refinement [dang2026selecting, Sections 5.2 and 6-7; Tables 4-5, 10] motivate these observable classes, which are an FTIP proposal. Write
\[ \tau _{\rm end}:=\inf \{t:e_{\rm term}(t)=1\},\quad \tau _{\rm ev}:=\inf \{t:e_{\rm ev}(t)=1\},\quad \tau _{\rm pass}:=\inf \{t:e_{\rm pass}(t)=1\}, \]\[ \tau _{\rm fail}:=\inf \{t:e_{\rm fail}(t)=1\},\quad \tau _{\rm rec}:=\inf \{t:e_{\rm rec}(t)=1\},\quad \tau _{\rm sat}:=\inf \{t:u(t)\geq u^{\rm sat}\}, \]with \(\inf \varnothing :=+\infty \). The receipt declares all indicators and the score as functions of the same run, so the following classes are replayable predicates rather than impressions about an agent's inner state.
\[ \operatorname {Prem}(T):=\mathbf 1[\tau _{\rm end}<\tau _{\rm ev}\lor (\tau _{\rm fail}<\tau _{\rm end}\land \tau _{\rm rec}\geq \tau _{\rm end})], \]\[ \operatorname {Prod}(T):=\mathbf 1[\tau _{\rm ev}<\tau _{\rm end}\land \tau _{\rm pass}<\tau _{\rm end}\land (\tau _{\rm fail}\geq \tau _{\rm end}\lor \tau _{\rm fail}<\tau _{\rm rec}<\tau _{\rm end})], \]\[ \operatorname {Over}(T):=\mathbf 1[\tau _{\rm sat}<\tau _{\rm end}\land \sum _{t=\tau _{\rm sat}}^{\tau _{\rm end}-1}n_{\rm prod}(t)=0]. \]A productive trace reaches evidence and a final verifier pass, and any failure before termination is followed by recovery. An over-persistent trace continues after saturation without another declared productive event. The experiment may refine \(n_{\rm prod}\) for a task family, but it must declare that predicate before comparing selectors.
Example. A retained build-repair trace [ftip-00P7]AGENTDRAFTED
Example. A retained build-repair trace [ftip-00P7]AGENTDRAFTED
The horizon and selective-refinement observations in [dang2026selecting, Sections 3-7] motivate the following finite classification. Consider a run whose task is to repair a failing build. The retained record contains the failing observation, the source edit, a test execution, and a final verifier pass. With the event interface of Definition [ftip-00P6], the test and verification steps contribute to \(e_{\rm ev}\), \(e_{\rm pass}\), and \(n_{\rm prod}\), so the record can satisfy \(\operatorname {Prod}(T)\).
If the test event is removed from the retained record, the same token budget can fail the productive predicate because the evidence chain is incomplete. If identical shell retries continue after \(\tau _{\rm sat}\) with no new productive event, \(\operatorname {Over}(T)\) can hold. This is a finite classification example; it does not claim that every short trace is better or that a model has an inner persistence objective.
Fixed-budget trace-selection protocol [ftip-00P3]AGENTDRAFTED
Fixed-budget trace-selection protocol [ftip-00P3]AGENTDRAFTED
The trace-selection intervention is a finite evaluation proposal. It compares horizon and selector choices at a declared retained budget while keeping the model, teacher, scaffold, task split, verifier, randomization law, and cost coordinates visible. The selective-refinement study supplies the comparison pattern; the typed interface, receipts, and estimators below are FTIP adaptations rather than source results [dang2026selecting, Sections 6-7; Tables 4-5, 10].
The route separates the experiment interface (Definition [ftip-00P8]), its receipt-derived quantities (Definition [ftip-00P9]), and a finite paired calculation (Example [ftip-00PA]). No result is claimed until an implementation supplies the declared receipts.
Definition. Finite trace-selection experiment [ftip-00P8]AGENTDRAFTED
Definition. Finite trace-selection experiment [ftip-00P8]AGENTDRAFTED
The selective-refinement study compares fixed-horizon data interventions under a declared training and evaluation boundary [dang2026selecting, Sections 6-7; Tables 4-5, 10]. A trace-selection experiment is the following finite typed record.
Fix the P0 lifecycle arm set \(\mathcal A\), its boundary map \(r:\mathcal A\to \mathcal J\), mask map \(M:\mathcal A\to \mathcal P(\{s,h,w\})\), and endowment \(E_0\) from § [ftip-00P0] and § [ftip-00OY]. Choose finite nonempty label sets
\[ \mathfrak H\subset \mathbb N,\qquad \mathfrak L,\qquad \mathfrak B\subset \mathbb N_{>0},\qquad \mathfrak D,\qquad \mathfrak R. \]A split map returns a triple
\[ \operatorname {split}:\mathfrak D\longrightarrow \{(Q_{\rm sel},Q_{\rm hold},Q_{\rm xb})\mid Q_{\rm sel},Q_{\rm hold},Q_{\rm xb}\subseteq \mathcal Q\text { are finite}\}, \]whose three outputs are pairwise disjoint and satisfy \(|Q_{\rm sel}|>0\), \(|Q_{\rm hold}|>0\); \(Q_{\rm xb}\) may be empty only when the experiment records that no cross-benchmark comparison is made. A randomization map \(\lambda _{\rm pair}:\mathfrak R\to \operatorname {Dist}(\mathcal G\times \mathcal G)\) supplies a joint source law for each paired comparison.
The experiment declares a finite, nonempty arm set \(\mathfrak A\subseteq \mathcal A\times \mathfrak H\times \mathfrak L\times \mathfrak B\times \mathfrak D\times \mathfrak R\). For each \(a\in \mathfrak A\), write its projections as
\[ (a_0(a),H_a,\ell _a,B_a,D_a,\eta _a),\qquad r_a:=r(a_0(a)),\quad M_a:=M(a_0(a)),\quad \mathcal R_a:=\lambda _{\rm pair}(\eta _a). \]The arm record additionally supplies one model, teacher, scaffold, verifier, task law, inference protocol, and componentwise budget. These objects are maps of \(a\), not implicit labels; paired arms must agree on every object except the factor named by their comparison. The split attached to \(D_a\) is written \((Q_{\rm sel,a},Q_{\rm hold,a},Q_{\rm xb,a})\); it also supplies a nonempty finite strategy-label set \(\mathfrak S_a\) and a receipt space \(\mathcal R_a^{\rm rec}\) containing a typed held-out outcome \(Y_a\in \mathcal Y_a\cup \{\bot \}\), a declared scalarization \(g_a:\mathcal Y_a\to \mathbb R\), and an admission field. For every paired comparison \((a,a')\), the record additionally declares the finite pairing space \(\mathcal P_{a,a'}:=(Q_{\rm hold,a}\cap Q_{\rm hold,a'}) \times \mathfrak S_a\times \mathfrak S_{a'}\) and a law \(\Lambda _{a,a'}\) on \(\mathcal G\times \mathcal G\times \mathcal P_{a,a'}\). The shared task coordinate in this law is the pairing key; the two strategy coordinates may differ.
For each arm, let \(\mathcal X^{\rm sel}_a\) be the finite candidate-pool space with \(1\leq B_a\leq |\mathcal X^{\rm sel}_a|\), and let \(\mathcal F^{\rm sel}_a\) be the sigma-field generated by the selection-time prefix, teacher-forced score, data-only trace metadata, and \(Q_{\rm sel,a}\). The metadata map excludes held-out outcomes, verifier outcomes, and post-selection continuation events. The selector is a measurable kernel with respect to this sigma-field
\[ \mathsf S_{a,\ell _a}:\mathcal X^{\rm sel}_a \longrightarrow \operatorname {Dist}\bigl (\{I\subseteq \mathcal X^{\rm sel}_a: |I|=B_a\}\bigr ). \]It therefore returns a retained index set of the declared size without access to held-out outcomes. Write \(\mathcal I_a:=\{I\subseteq \mathcal X^{\rm sel}_a:|I|=B_a\}\). A run kernel
\[ \mathsf K^{\rm run}_{a,\ell _a}: \mathcal X^{\rm sel}_a\times \mathcal I_a\times \mathcal G \times \mathcal Q\times \mathfrak S_a \longrightarrow \operatorname {Dist}(\mathcal R_a^{\rm rec}) \]maps a candidate pool, its retained index set, one component of the paired source draw, a task, and its arm-specific strategy coordinate to a receipt with an event sequence, task and strategy labels, final verifier outcome, typed held-out outcome, admission field, state and artifact hashes, and the charged token, tool, storage, restart, discarded trace, and verification costs, with exactly \(H_a+1\) event slots and a timeout receipt at the final slot when needed. For a paired comparison, \(\Lambda _{a,a'}\) supplies a common held-out task and the two strategy coordinates, while \(\mathcal R_a\) supplies the two source components before the kernels are applied. Thus an arm defines maps and kernels that use the selector output to produce replayable receipts; it does not merely list factors whose later meaning is left implicit.
The reset transition is \(\mathsf {Reset}_{r_a,M_a}\) from § [ftip-00P0]. Horizon, selector, budget, split, and randomization are therefore attached to a concrete P0 state boundary and a concrete run kernel. This is an empirical protocol definition, not a theorem or a claim that any selector improves behavior.
Definition. Receipt metrics and paired contrasts [ftip-00P9]AGENTDRAFTED
Definition. Receipt metrics and paired contrasts [ftip-00P9]AGENTDRAFTED
The source compares retained-horizon choices under declared task and evaluation boundaries [dang2026selecting, Sections 6-7; Tables 4-5, 10]. Fix an arm \(a\in \mathfrak A\) from Definition [ftip-00P8] and a positive run count \(N_a\). Each receipt \(R_{a,i}\) exposes a finite event sequence \((e^{\rm term},e^{\rm ev},e^{\rm pass},e^{\rm fail},e^{\rm rec}, n^{\rm prod})_{t=0}^{H_a}\), a task label \(q_{a,i}\), a strategy label \(s_{a,i}\), a measurable task-value score \(u_{a,i}(t)\), a declared saturation threshold \(u_a^{\rm sat}\), and a typed held-out outcome \(Y_{a,i}\in \mathcal Y_a\cup \{\bot \}\), final verifier outcome \(v_{a,i}\), and complete-admission indicator \(A_{a,i}\). Define \(A_{a,i}:=\mathbf 1[q_{a,i}\in Q_{\rm hold,a}\land v_{a,i}=1 \land Y_{a,i}\in \mathcal Y_a]\); when \(A_{a,i}=0\), set \(Y_{a,i}:=\bot \). The receipt contract emits a terminal event by \(H_a\); an execution that would not terminate naturally receives a timeout terminal event at \(H_a\) and \(A_{a,i}=0\). Put \(\overline {\mathbb N}:=\mathbb N\cup \{+\infty \}\) and \(\inf \varnothing :=+\infty \).
\[ \tau ^{\rm end}_{a,i}:=\inf \{t:e^{\rm term}_{a,i}(t)=1\},\quad \tau ^{\rm ev}_{a,i}:=\inf \{t:e^{\rm ev}_{a,i}(t)=1\},\quad \tau ^{\rm pass}_{a,i}:=\inf \{t:e^{\rm pass}_{a,i}(t)=1\}, \]\[ \tau ^{\rm fail}_{a,i}:=\inf \{t:e^{\rm fail}_{a,i}(t)=1\},\quad \tau ^{\rm rec}_{a,i}:=\inf \{t:e^{\rm rec}_{a,i}(t)=1\},\quad \tau ^{\rm sat}_{a,i}:=\inf \{t:u_{a,i}(t)\geq u_a^{\rm sat}\}. \]Define the receipt predicates
\[ \begin {aligned} I^{\rm pre}_{a,i}&:=\mathbf 1[\tau ^{\rm end}_{a,i}<\tau ^{\rm ev}_{a,i}],\\ I^{\rm rec}_{a,i}&:=\mathbf 1[\tau ^{\rm fail}_{a,i}<\tau ^{\rm rec}_{a,i}<\tau ^{\rm end}_{a,i}],\\ I^{\rm prod}_{a,i}&:=\mathbf 1[\tau ^{\rm ev}_{a,i}<\tau ^{\rm end}_{a,i} \land \tau ^{\rm pass}_{a,i}<\tau ^{\rm end}_{a,i} \land (\tau ^{\rm fail}_{a,i}\geq \tau ^{\rm end}_{a,i} \lor I^{\rm rec}_{a,i}=1)],\\ I^{\rm over}_{a,i}&:=\mathbf 1[\tau ^{\rm sat}_{a,i}<\tau ^{\rm end}_{a,i} \land \sum _{t=\tau ^{\rm sat}_{a,i}}^{\tau ^{\rm end}_{a,i}-1} n^{\rm prod}_{a,i}(t)=0]. \end {aligned} \]Here \(n^{\rm prod}_{a,i}(t)\) is a declared productive-novelty indicator in the receipt, and \(I^{\rm rec}\) is zero when no failure precedes recovery. The five run rates are functions of the receipts, with the declared denominator \(N_a\):
\[ (\widehat p_a^{\rm pre},\widehat p_a^{\rm prod},\widehat p_a^{\rm over}, \widehat p_a^{\rm rec},\widehat p_a^{\rm pass}) :=\frac 1{N_a}\sum _{i=1}^{N_a} (I^{\rm pre}_{a,i},I^{\rm prod}_{a,i},I^{\rm over}_{a,i}, I^{\rm rec}_{a,i},\mathbf 1[\tau ^{\rm pass}_{a,i}<\tau ^{\rm end}_{a,i}]). \]For the finite held-out set, task and strategy coverage are
\[ \widehat C^{\rm task}_a:= \frac {|\{q\in Q_{\rm hold,a}:\exists i,\ q_{a,i}=q,\ A_{a,i}=1\}|} {|Q_{\rm hold,a}|},\qquad \widehat C^{\rm strat}_a:= \frac {|\{s\in \mathfrak S_a:\exists i,\ s_{a,i}=s,\ A_{a,i}=1\}|} {|\mathfrak S_a|}, \]where \(\mathfrak S_a\) is a declared nonempty strategy-label set. Every receipt reports both positive denominators and the admission rule.
For two paired arms \(a\) and \(a'\) that differ in one declared factor, let \(N:=\min (N_a,N_{a'})\). Define the common admitted index set \(J_{a,a'}:=\{i\leq N:A_{a,i}=A_{a',i}=1\}\) and \(N_{\rm pair}:=|J_{a,a'}|\). For \(i\in J_{a,a'}\), let \(Y_{a,i}\) and \(Y_{a',i}\) be their admitted held-out outcomes under the shared pairing law \(\Lambda _{a,a'}\), so \(q_{a,i}=q_{a',i}\). Compare their declared scalarizations \(g_a(Y_{a,i})\) and \(g_{a'}(Y_{a',i})\). When \(N_{\rm pair}\geq 2\), the primary finite contrast and its paired sample variance are
\[ \widehat \Delta _{a,a'}:= \frac 1{N_{\rm pair}}\sum _{i\in J_{a,a'}} \bigl (g_a(Y_{a,i})-g_{a'}(Y_{a',i})\bigr ),\qquad \widehat V_{a,a'}:= \frac 1{N_{\rm pair}-1}\sum _{i\in J_{a,a'}} \bigl ((g_a(Y_{a,i})-g_{a'}(Y_{a',i}))-\widehat \Delta _{a,a'}\bigr )^2. \]When \(N_{\rm pair}=1\), report the single paired contrast but set \(\widehat V_{a,a'}:=\bot \); when \(N_{\rm pair}=0\), the paired contrast is undefined and the missingness is reported. These are finite estimators under the declared arm, split, admission rule, and coupling; they are not a universal selector law.
Example. A paired trace-selection calculation [ftip-00PA]AGENTDRAFTED
Example. A paired trace-selection calculation [ftip-00PA]AGENTDRAFTED
The selective-refinement comparison motivates contrasting repeatability and coverage under a fixed retained budget [dang2026selecting, Sections 6-7; Tables 4-5, 10]. Consider two arms from Definition [ftip-00P8] with the same P0 boundary, model, task split, verifier, budget, and paired assignment law. They differ only in the selector: \(a\) retains the highest teacher-forced scores and \(a'\) retains a coverage-stratified subset. Both have \(Q_{\rm hold}=\{q_1,q_2\}\) and \(\mathfrak S=\{s_1,s_2\}\). The paired assignment law gives the same held-out task at indices 1 and 2; arm \(a'\) has one additional admitted coverage run at index 3. Take \(g_a=g_{a'}=\operatorname {id}_{\{0,1\}}\). The receipts are
\[ \begin {array}{c|cc|ccc} &q_{a,i}&s_{a,i}&A_{a,i}&I^{\rm prod}_{a,i}&Y_{a,i}\\\hline i=1&q_1&s_1&1&1&1\\ i=2&q_1&s_1&1&1&0 \end {array} \qquad \begin {array}{c|cc|ccc} &q_{a',i}&s_{a',i}&A_{a',i}&I^{\rm prod}_{a',i}&Y_{a',i}\\\hline i=1&q_1&s_1&1&1&1\\ i=2&q_1&s_1&1&1&1\\ i=3&q_2&s_2&1&1&1 \end {array} \]The first two rows are the common paired indices, so \(N_a=2\), \(N_{a'}=3\), and \(N_{\rm pair}=2\). Both arms have \(\widehat p^{\rm prod}=1\); the third row is included in arm \(a'\)'s coverage and run-rate denominators but not in the paired contrast. Thus \(\widehat C^{\rm task}_a=\widehat C^{\rm strat}_a=\tfrac 12\) and \(\widehat C^{\rm task}_{a'}=\widehat C^{\rm strat}_{a'}=1\), while \(\widehat \Delta _{a,a'}=-\tfrac 12\). The calculation shows why a repeatability rate alone cannot identify coverage: the two selectors have the same productive rate but different admitted task and strategy support. This is a finite FTIP construction using the typed receipt and pairing definitions, not a source result.
With the trace schema and the fixed-budget protocol now in scope, the FTIP boundary is operational: an admitted trace must preserve the declared decision, evidence, verification, and recovery events, and every selector comparison must report the finite run rates, held-out task and strategy coverage, and charged selection/storage/restart costs defined in § [ftip-00P3]. A result may claim a selection benefit only when its immutable arm, split, seed, and randomization receipt supports that comparison.
Recursive harnesses and archive envelopes [ftip-00EH]AGENTDRAFTED
Recursive harnesses and archive envelopes [ftip-00EH]AGENTDRAFTED
Recursive harnesses can be modeled as fixed-driver transformations of traces, code, and task descriptions. Sections 2.2--2.4 of [kim2026metanrecursive] supply the fixed meta-operation, conditioning, stopping, and archive context; Sections 3.1--3.4 are empirical architecture comparisons. The finite consequences below are proved locally.
Fixed drivers and recursive layers [ftip-00EI]AGENTDRAFTED
Fixed drivers and recursive layers [ftip-00EI]AGENTDRAFTED
A fixed meta-operation generates mutable layer artifacts. Their composition determines the resulting recursive wrapper.
Definition. Recursive layer state [ftip-00EJ]AGENTDRAFTED
Definition. Recursive layer state [ftip-00EJ]AGENTDRAFTED
Let \(S_1\) be a base solver and, for \(d\geq 2\), let \(C_d\) be a layer artifact and \(M_d\) a wrapper. The depth-\(d\) solver is \(S_d=M_d(C_d,S_{d-1})\). The layer state is \(\Lambda _d=(C_d,S_d)\).
A layer is a harness transformation when it changes \(C_d\) or the wrapper context while leaving the executable base weights in \(S_1\) fixed.
Definition. Fixed meta-operation [ftip-00EK]AGENTDRAFTED
Definition. Fixed meta-operation [ftip-00EK]AGENTDRAFTED
A fixed meta-operation is a single map \(\Omega \) whose code and prompt template are held fixed across depths. For task set \(\mathcal T\), traces \(\boldsymbol \tau _{d-1}\), code stack \([C_2,\ldots ,C_{d-1}]\), and depth \(d\),
\[\Omega (\boldsymbol \tau _{d-1},[C_2,\ldots ,C_{d-1}],\mathcal T,d)=C_d.\]Only the input to \(\Omega \) changes with depth; this is a declared protocol condition, not a claim that every implementation obeys it.
Definition. Trace-and-code input [ftip-00EL]AGENTDRAFTED
Definition. Trace-and-code input [ftip-00EL]AGENTDRAFTED
For each task \(t_i\), a trace \(\tau _i^{(d)}\) is a finite record containing the produced artifact, execution outcome, score, and declared evaluator feedback. The depth-\(d\) input to \(\Omega \) is the pair \((\boldsymbol \tau _{d-1},[C_2,\ldots ,C_{d-1}])\); a flat refiner that sees only \(\boldsymbol \tau \) has a strictly smaller declared input when the code stack is not recoverable from the traces.
Theorem. Nested wrapper composition [ftip-00EM]AGENTDRAFTED
Theorem. Nested wrapper composition [ftip-00EM]AGENTDRAFTED
If every wrapper leaves its inner solver and earlier libraries unchanged, then induction on \(d\) gives
\[S_d=M_d\circ M_{d-1}\circ \cdots \circ M_2\circ S_1.\]Proof. The case \(d=2\) is the definition. Substituting the induction hypothesis into \(S_d=M_d(C_d,S_{d-1})\) gives the displayed composition.
Theorem. Finite trace growth under recursive wrapping [ftip-00EN]AGENTDRAFTED
Theorem. Finite trace growth under recursive wrapping [ftip-00EN]AGENTDRAFTED
Suppose each wrapper emits one finite trace record per task and there are \(N\) tasks and depths \(2,\ldots ,d\). The audit log contains at most \(N(d-1)\) depth-tagged records, in addition to the base records. This is a counting fact; it says nothing about trace quality or score improvement.
Proof. There are \(d-1\) wrapped depths and \(N\) records at each depth, so the product counts all records.
Example. Code explains a regression that traces alone cannot [ftip-00EO]AGENTDRAFTED
Example. Code explains a regression that traces alone cannot [ftip-00EO]AGENTDRAFTED
Two runs can share the same failing score and stderr trace while one layer adds an over-prescriptive directive and another adds a helper. Recording the code artifact alongside the trace permits a later layer to roll back the directive without discarding the helper. This is an audit example, not a guarantee that a recursive driver finds the rollback.
Archives and stopping rules [ftip-00EP]AGENTDRAFTED
Archives and stopping rules [ftip-00EP]AGENTDRAFTED
A finite archive can contain several candidate chains, while execution uses a single selected chain. A stopping rule determines when recursive generation ends.
Definition. Finite recursive archive [ftip-00EQ]AGENTDRAFTED
Definition. Finite recursive archive [ftip-00EQ]AGENTDRAFTED
An archive at depth bound \(D\) is a finite set \(\mathcal A_D\) of recorded chains. Each chain has the form
\[a=(C_2,\ldots ,C_{d_a}),\qquad 1\leq d_a\leq D.\]Each chain stores its evaluation record and resource cost. Archive membership is a protocol state, not a learned weight update.
Definition. Archive score envelope [ftip-00ER]AGENTDRAFTED
Definition. Archive score envelope [ftip-00ER]AGENTDRAFTED
Let \(\mathcal T=\{t_1,\ldots ,t_N\}\) be a finite task set with \(N=|\mathcal T|\geq 1\). For every chain \(a\) in the finite archive, let \(s_i(a)\in \mathbb R\) be its score on task \(t_i\) under a declared common evaluation law. Define its whole-chain mean by
\[J(a)=N^{-1}\sum _{i=1}^N s_i(a).\]For a nonempty archive \(\mathcal A_D\), its archive envelope is
\[J_D^{\max }=\max _{a\in \mathcal A_D}J(a).\]The finite real-valued maximum is attained by at least one archived chain. It scores a single chain across all tasks; it does not select a different chain for each task.
Deployment eligibility is a separate condition. A target configuration specifies which recorded chains can execute with their stated behavior and resource requirements. Maximizing over that eligible subset gives a deployable archive choice when the subset is nonempty; if it is empty, there is no eligible archived choice. Applying the recorded score to deployment additionally requires the same evaluation law. Records from different configurations alone do not establish these conditions.
Lemma. Archive envelope dominates its incumbent [ftip-00ES]AGENTDRAFTED
Lemma. Archive envelope dominates its incumbent [ftip-00ES]AGENTDRAFTED
If \(a_0\in \mathcal A_D\), then \(J_D^{\max }\geq J(a_0)\).
Proof. The maximum of a finite nonempty set is at least each member, in particular \(a_0\). No claim about an unseen task follows.
Theorem. Finite archive selection bound [ftip-00ET]AGENTDRAFTED
Theorem. Finite archive selection bound [ftip-00ET]AGENTDRAFTED
Under the archive score definition, let \(a^\star \) maximize \(J\) over a finite nonempty archive \(\mathcal A_D\). Let \(\delta \in \mathbb R\) with \(\delta \geq 0\), and let \(\hat a\in \mathcal A_D\) satisfy \(J(\hat a)\geq J(a^\star )-\delta \). Then
\[0\leq J(a^\star )-J(\hat a)\leq \delta .\]
Proof.
Proof.
Membership of \(\hat a\) in the same archive gives \(J(\hat a)\leq J(a^\star )\) by maximality. Rearranging the approximation inequality gives the upper bound.
This is a finite selection statement under the same evaluation law; it is not an optimizer-convergence or generalization theorem.
Conditioning, interference, and finite protocol records [ftip-00EU]AGENTDRAFTED
Conditioning, interference, and finite protocol records [ftip-00EU]AGENTDRAFTED
Conditional strategy and tactic composition can produce interference. Auditing a recursive run requires its task, conditioning, execution, and cost records.
Definition. Strategy and tactic configuration [ftip-00EV]AGENTDRAFTED
Definition. Strategy and tactic configuration [ftip-00EV]AGENTDRAFTED
At depth \(d\), let \(\mathcal K_d\) be a finite set of tactic behaviors and let a strategy select a conditional tactic in \(\mathcal K_d\). A realized configuration is \((k_2,\ldots ,k_n)\). The notation records expressible choices, not the number of choices an implementation actually discovers.
Lemma. Conditional configuration upper bound [ftip-00EW]AGENTDRAFTED
Lemma. Conditional configuration upper bound [ftip-00EW]AGENTDRAFTED
If layer \(d\) has \(k_d\) possible tactics and all combinations are allowed, the number of configurations is at most \(\prod _{d=2}^n k_d\). An unconditioned flat choice with the same layerwise menus has at most \(\sum _{d=2}^n k_d\) listed choices.
Proof. The first count is the cardinality of a Cartesian product; the second is the cardinality of a disjoint menu union. These are upper bounds only.
Example. Product versus sum is not a measured gain [ftip-00EX]AGENTDRAFTED
Example. Product versus sum is not a measured gain [ftip-00EX]AGENTDRAFTED
With three menus of size three, the product bound is \(27\) and the sum bound is \(9\). A protocol that never emits most combinations can realize far fewer than \(27\); the arithmetic does not establish a benchmark improvement.
Example. Layer interference and rollback [ftip-00EY]AGENTDRAFTED
Example. Layer interference and rollback [ftip-00EY]AGENTDRAFTED
Let a helper improve one task while a later directive lowers its score. The archive can retain the earlier helper chain and a later layer can remove the directive. The example separates a compositional possibility from a proof that any driver detects or repairs interference.
Remark. Recursion is not a quality guarantee [ftip-00EZ]AGENTDRAFTED
Remark. Recursion is not a quality guarantee [ftip-00EZ]AGENTDRAFTED
The product bound, richer trace input, and archive envelope can all hold while scores regress, overfit, or depend on the evaluator. The source reports empirical ablations and layer roles in Sections 3.1--3.4; those observations do not become FTIP theorems or capability claims here.
Stopping and admission under fixed tasks and budgets [ftip-00F0]AGENTDRAFTED
Stopping and admission under fixed tasks and budgets [ftip-00F0]AGENTDRAFTED
Definition. Recursive run record [ftip-00F1]AGENTDRAFTED
Definition. Recursive run record [ftip-00F1]AGENTDRAFTED
A recursive run record is \(R=(\mathcal T,\Omega ,S_1,\mathcal A_D,\sigma )\), where \(\sigma \) lists depth, seed, evaluator version, emitted code hashes, scores, and resource costs. A record is replayable only relative to these declared inputs and versions.
Definition. Convergence stopping rule [ftip-00F2]AGENTDRAFTED
Definition. Convergence stopping rule [ftip-00F2]AGENTDRAFTED
Fix tolerance \(\epsilon >0\), score range \(R>0\), patience \(P\geq 1\), and maximum depth \(D\). A linear recursive run stops when no emitted layer improves the mean score by more than \(\epsilon R\) for \(P\) consecutive layers, or when the driver emits empty code, or when depth \(D\) is reached.
Lemma. Finite stopping bound [ftip-00F3]AGENTDRAFTED
Lemma. Finite stopping bound [ftip-00F3]AGENTDRAFTED
Under the rule in Definition [ftip-00F2], a run that reaches its depth cap emits at most \(D-1\) wrapped layers. If it stops earlier, it emits no more than this many. This bound is combinatorial and does not imply convergence of scores.
Theorem. Budget-preserving layer admission [ftip-00F4]AGENTDRAFTED
Theorem. Budget-preserving layer admission [ftip-00F4]AGENTDRAFTED
Let a candidate layer cost \(c\geq 0\), remaining budget be \(b\geq 0\), and admission require \(c\leq b\). After admission, set \(b'=b-c\); then \(b'\geq 0\) and the total admitted cost is at most the initial budget.
Proof. Subtracting a nonnegative cost no larger than \(b\) preserves nonnegativity; induction over admissions gives the total bound.
Example. Rollback preserves the base solver [ftip-00F5]AGENTDRAFTED
Example. Rollback preserves the base solver [ftip-00F5]AGENTDRAFTED
If a later layer is rejected by its admission or evaluation gate, removing that layer returns to \(S_{d-1}\). This is a harness rollback, not a reversal of weight training and not evidence that the rejected layer was unsafe.
Remark. What the recursive source reports [ftip-00F6]AGENTDRAFTED
Remark. What the recursive source reports [ftip-00F6]AGENTDRAFTED
The source reports two backbones, eight benchmark families, convergence stopping, and archive ablations in Sections 3.1--3.4 of [kim2026metanrecursive]; its fixed-driver, conditioning, stopping, and archive setup is described in Sections 2.2--2.4. These are empirical comparisons under its task, model, and budget choices; they are not universal depth, stability, or capability theorems.
Remark. Recursive harnesses with fixed evaluators and versions [ftip-00F7]AGENTDRAFTED
Remark. Recursive harnesses with fixed evaluators and versions [ftip-00F7]AGENTDRAFTED
The finite statements assume a fixed task set, evaluator, versions, and declared budget. They do not transfer to weight learning, RLVR optimization, unbounded self-modification, or capability acquisition without new hypotheses.
Example. Whole-chain maximum and per-task oracle [ftip-00F8]AGENTDRAFTED
Example. Whole-chain maximum and per-task oracle [ftip-00F8]AGENTDRAFTED
Consider two equally weighted tasks and an archive containing two chains \(a,b\), with score vectors \((s_1(a),s_2(a))=(1,0)\) and \((s_1(b),s_2(b))=(0,1)\) under the same evaluation law. The archive envelope is
\[J(a)=J(b)=J_D^{\max }=\frac 12.\]Either chain attains this maximum. In contrast, a per-task oracle has value
\[\frac 12\sum _{i=1}^2\max _{c\in \{a,b\}}s_i(c)=1.\]The oracle selects \(a\) on the first task and \(b\) on the second. A configuration constrained to select one archived chain before observing task identity obtains mean \(1/2\) in this example. If task-dependent routing is permitted, the resulting combined policy must itself be declared and evaluated, including its routing and execution costs. The oracle value is not automatically the score of either archived chain.
Incompatible execution configurations create a separate obstacle: an archived maximizing chain may be ineligible for a named target configuration. That feasibility restriction does not alter the distinction between the two score functionals above.
Reward, verifier, and environment failure modes [ftip-00DX]AGENTDRAFTED
Reward, verifier, and environment failure modes [ftip-00DX]AGENTDRAFTED
A reward channel, a verifier, and the environment transition law describe different aspects of an interaction. A high score in one channel is not by itself a utility, support, or capability-acquisition statement.
The catalog of [dharna2026aifindsway] supplies heterogeneous empirical counterexamples and provenance, not rates or a general theorem.
Reward semantics and environment coupling [ftip-00DY]AGENTDRAFTED
Reward semantics and environment coupling [ftip-00DY]AGENTDRAFTED
The same response can be scored by several channels while the environment can assign different transitions or hidden consequences. A score, a state transition, and a hidden consequence are distinct functions of the interaction.
Definition. Named reward channel [ftip-00DZ]AGENTDRAFTED
Definition. Named reward channel [ftip-00DZ]AGENTDRAFTED
For a fixed task \(x\), let \(\mathcal Y_x\) be a finite response set and let a named reward channel be a map \(r:\mathcal Y_x\to \mathbb R\). A utility map \(u:\mathcal Y_x\to \mathbb R\) is a separate evaluation quantity.
If an interaction has state space \(\mathcal S\), action space \(\mathcal A\), and transition kernel \(K(\mathord {\cdot }\mid s,a)\), then \(K\) is a third object: changing \(K\) can change consequences without changing \(r\).
Definition. Verifier channel and false acceptance [ftip-00E0]AGENTDRAFTED
Definition. Verifier channel and false acceptance [ftip-00E0]AGENTDRAFTED
A verifier channel is a map \(V:\mathcal Y_x\to \{0,1\}\). Given a validity map \(U:\mathcal Y_x\to \{0,1\}\), a false-accept event is
\[F=\{y\in \mathcal Y_x:V(y)=1\ \text {and}\ U(y)=0\}.\]The event depends on the declared verifier and validity test. It is not identified by a scalar reward unless equivalence with that reward criterion is an explicit assumption.
Remark. What reward-hacking anecdotes establish [ftip-00E1]AGENTDRAFTED
Remark. What reward-hacking anecdotes establish [ftip-00E1]AGENTDRAFTED
Sections 4.1--4.2 and 7.2--7.3 of [dharna2026aifindsway] catalogue reward, score, environment, and evaluator-target anecdotes. The source gives 26 curated firsthand anecdotes involving more than 100 researchers; it does not provide a common sampling frame, base rates, or causal effect estimates.
Accordingly, this section uses the paper as an empirical counterexample catalog. The finite statements that follow are proved here and do not claim to summarize all training systems.
Theorem. Uniform proxy disagreement gives two-epsilon regret [ftip-00E2]AGENTDRAFTED
Theorem. Uniform proxy disagreement gives two-epsilon regret [ftip-00E2]AGENTDRAFTED
Let \(\mathcal Y_x\) be finite, let \(u,r:\mathcal Y_x\to \mathbb R\), and assume \(|r(y)-u(y)|\le \varepsilon \) for every \(y\), with \(\varepsilon \ge 0\). If \(y^\star \) maximizes \(u\) and \(\widehat y\) maximizes \(r\), then
\[u(y^\star )-u(\widehat y)\le 2\varepsilon .\]Indeed, \(u(y^\star )\le r(y^\star )+\varepsilon \le r(\widehat y)+\varepsilon \le u(\widehat y)+2\varepsilon \). This is a finite same-class decision bound, not an optimization, distribution-shift, or capability theorem.
Example. Equal nominal score, different utility [ftip-00E3]AGENTDRAFTED
Example. Equal nominal score, different utility [ftip-00E3]AGENTDRAFTED
Take \(\mathcal Y_x=\{a,b\}\), with \(r(a)=r(b)=1\) but \(u(a)=1\) and \(u(b)=0\). Every reward maximizer is a nominal tie, while only \(a\) is utility optimal. The example shows why a score equality does not establish intent or validity.
Verifier false accepts [ftip-00E4]AGENTDRAFTED
Verifier false accepts [ftip-00E4]AGENTDRAFTED
False acceptance is an event over candidates and a declared validity test. Repeated auditing can bound its occurrence, but a bound on existence is not automatically a bound on the selected output.
Definition. False-accept event for a candidate [ftip-00E5]AGENTDRAFTED
Definition. False-accept event for a candidate [ftip-00E5]AGENTDRAFTED
For candidate index \(i\), let \(I_i\in \{0,1\}\) indicate invalidity and let \(A_i\in \{0,1\}\) indicate verifier acceptance. Define \(F_i=\{I_i=1,A_i=1\}\). Write \(q_i=\Pr (I_i=1)\). If \(q_i>0\), write \(\eta _i=\Pr (A_i=1\mid I_i=1)\); if \(q_i=0\), set \(\eta _i=0\). Then \(\Pr (F_i)=q_i\eta _i\).
No independence or identical-distribution hypothesis is part of this definition.
Lemma. Union bound for repeated false accepts [ftip-00E6]AGENTDRAFTED
Lemma. Union bound for repeated false accepts [ftip-00E6]AGENTDRAFTED
For finitely many candidate events from Definition [ftip-00E5],
\[\Pr \left (\bigcup _{i=1}^{N}F_i\right )\le \sum _{i=1}^{N}\Pr (F_i) =\sum _{i=1}^{N}q_i\eta _i.\]This is the union bound and requires no independence. If every marginal is at most \(\eta \), the right side is at most \(N\eta \).
Example. Existence of a false accept is not selected-output failure [ftip-00E7]AGENTDRAFTED
Example. Existence of a false accept is not selected-output failure [ftip-00E7]AGENTDRAFTED
Suppose two candidates are produced: candidate 1 is invalid and falsely accepted, while candidate 2 is valid and rejected by a separate score tie-break. Then \(\bigcup _iF_i\) occurs, but a selection rule that always chooses candidate 2 outputs a valid response. Thus an existence probability and a selected-output probability coincide only after the selection law is specified.
Environment and oversight targets [ftip-00E8]AGENTDRAFTED
Environment and oversight targets [ftip-00E8]AGENTDRAFTED
An evaluator can be an optimization target while hidden environment consequences remain outside its score. A policy can therefore improve the measured score while changing an unmeasured environmental outcome.
Definition. Environment exploit [ftip-00E9]AGENTDRAFTED
Definition. Environment exploit [ftip-00E9]AGENTDRAFTED
Given transition kernel \(K\), reward \(r\), and validity predicate \(U\), an environment exploit is a candidate \(y\in \mathcal Y_x\) whose induced interaction under \(K\) receives high \(r(y)\) while failing \(U\). The definition is relative to the declared kernel, horizon, and validity test; it is not a universal property of a model.
Example. Same reward, different transition semantics [ftip-00EA]AGENTDRAFTED
Example. Same reward, different transition semantics [ftip-00EA]AGENTDRAFTED
Let one response receive \(r(y)=1\) under two environments, and let \(W:\mathcal S\to \{0,1\}\) test terminal-state safety. In \(K_1\), its next state \(s_1\) has \(W(s_1)=1\); in \(K_2\), the same observed response enters \(s_2\) with \(W(s_2)=0\). The reward channel alone cannot distinguish the two transition semantics, so equal reward does not certify safe consequences.
Example. Evaluator-target behavior [ftip-00EB]AGENTDRAFTED
Example. Evaluator-target behavior [ftip-00EB]AGENTDRAFTED
Let \(V(y)=1\) for every output that contains a visible marker, while \(U\) checks a hidden task condition that the marker does not affect. A policy that optimizes \(V\) can improve its observed score while leaving \(U\) unchanged or worse. This is a finite illustration of evaluator targeting, not a claim about the frequency of such behavior.
Remark. No base rates or causal estimates [ftip-00EC]AGENTDRAFTED
Remark. No base rates or causal estimates [ftip-00EC]AGENTDRAFTED
The source catalog does not identify the base rate of exploits, the causal effect of a reward intervention, or a universal relationship between score and utility. Heterogeneous anecdotes therefore motivate audit questions and failure tests, not population-level probabilities.
Finite remediation protocol [ftip-00ED]AGENTDRAFTED
Finite remediation protocol [ftip-00ED]AGENTDRAFTED
A remediation protocol records what was scored, what was audited, and which environment and verifier versions were used. It may reject candidates before a commit, but its guarantee is only the finite event bound proved below.
Definition. Audit record [ftip-00EE]AGENTDRAFTED
Definition. Audit record [ftip-00EE]AGENTDRAFTED
An audit record is a tuple containing candidate identity, evaluator and verifier version, environment or transition-kernel version, invalidity tests, random seed, evidence pointers, and adjudicator decision. A record is complete only when these fields are bound to the candidate and the protocol run.
Proposition. Finite audit-gate bound [ftip-00EF]AGENTDRAFTED
Proposition. Finite audit-gate bound [ftip-00EF]AGENTDRAFTED
Let \(N\in \mathbb N_{\geq 1}\) and \(0\leq \eta \leq 1\). Assume these \(N\) candidates are audited and each invalid candidate is falsely accepted with marginal probability at most \(\eta \). Then the probability that some invalid candidate is accepted is at most \(N\eta \), by the union bound of Lemma [ftip-00E6]. This conclusion does not require independence.
The statement bounds existence of an accepted invalid candidate. A selected output guarantee additionally requires a typed selection rule and its relation to the audit decisions.
Remark. Verifier sensitivity and unmeasured failures [ftip-00EG]AGENTDRAFTED
Remark. Verifier sensitivity and unmeasured failures [ftip-00EG]AGENTDRAFTED
These finite channel distinctions do not prove reward hacking rates, capability acquisition, or safety of a deployed agent. The next questions are to measure verifier sensitivity, environment changes, selection rules, and independent audit power under a declared protocol.
Reliability protocol and failure taxonomy [ftip-00GR]AGENTDRAFTED
Reliability protocol and failure taxonomy [ftip-00GR]AGENTDRAFTED
A reliability protocol binds an evaluation to its durable state, replay inputs, and audit record. Execution and grading failures can invalidate a measurement even when the reported benchmark score improves.
Measurement and contamination controls [ftip-00GS]AGENTDRAFTED
Measurement and contamination controls [ftip-00GS]AGENTDRAFTED
Convention. Evidence required for a reliability claim [ftip-00GT]AGENTDRAFTED
Convention. Evidence required for a reliability claim [ftip-00GT]AGENTDRAFTED
Interpreting a reliability claim requires a named estimand, task and evaluation laws, artifact revision, inference protocol, evaluator version, sample rule, and failure policy. Missing coordinates are unknown rather than implicitly held fixed.
Definition. Contamination record [ftip-00GU]AGENTDRAFTED
Definition. Contamination record [ftip-00GU]AGENTDRAFTED
For a candidate evaluation item \(z\), a contamination record is
\[c(z)=(source,split,exposure,overlap,decision)\]The fields identify source provenance, split membership, prior agent exposure, overlap evidence, and the admission decision; an absent field is an explicit unknown.
Definition. A contamination predicate [ftip-00GV]AGENTDRAFTED
Definition. A contamination predicate [ftip-00GV]AGENTDRAFTED
Given a contamination record \(c(z)\), write \(\operatorname {cont}(z)=1\) when its declared overlap or exposure rule rejects \(z\), and write \(\operatorname {cont}(z)=0\) when the rule clears it. The predicate belongs to the protocol, not to a model’s score.
Definition. An uncontaminated evaluation slice [ftip-00GW]AGENTDRAFTED
Definition. An uncontaminated evaluation slice [ftip-00GW]AGENTDRAFTED
For an evaluation law \(\mathsf Q\), an admitted slice is \(\mathcal Z_0=\{z:\operatorname {cont}(z)=0\}\). Its reported score is conditioned on the declared slice law; removing contaminated items does not preserve the original estimand unless the law is unchanged by construction.
Definition. A paired comparison design [ftip-00GX]AGENTDRAFTED
Definition. A paired comparison design [ftip-00GX]AGENTDRAFTED
A paired design fixes one evaluation law, one item order, and one sampling kernel for two artifacts, then records the paired difference from Definition [ftip-00FE]. Any item-level exclusion is applied before seeing the paired outcomes or is declared as an adaptive rule.
Lemma. Pairing preserves the declared marginal target [ftip-00GY]AGENTDRAFTED
Lemma. Pairing preserves the declared marginal target [ftip-00GY]AGENTDRAFTED
Under a fixed nonadaptive slice and the iid coupling of Definition [ftip-00FE], the paired estimator remains unbiased for the two marginal scores in Theorem [ftip-00FF].
Proof.
Proof.
Condition on the fixed slice. The coupling has the stated marginals, so the proof of Theorem [ftip-00FF] applies without changing either expectation.
Example. A contamination decision can change the estimand [ftip-00GZ]AGENTDRAFTED
Example. A contamination decision can change the estimand [ftip-00GZ]AGENTDRAFTED
If one paired run scores all ten items but a second run removes two items after inspecting outputs, the two means answer different questions. A report must expose the removal rule and the resulting slice law.
Remark. Scope of measurement methodology [ftip-00H0]AGENTDRAFTED
Remark. Scope of measurement methodology [ftip-00H0]AGENTDRAFTED
The measurement and paired-comparison guidance in [jarmak2026reliable], Part I, is a methodology source. It motivates contamination ledgers and matched comparisons; it supplies no universal contamination detector or statistical guarantee.
Grader calibration [ftip-00H1]AGENTDRAFTED
Grader calibration [ftip-00H1]AGENTDRAFTED
Definition. A typed grading rubric [ftip-00H2]AGENTDRAFTED
Definition. A typed grading rubric [ftip-00H2]AGENTDRAFTED
A grading rubric is \(R=(\mathcal Z,\mathcal L,g,v)\): outcome space, finite label set, scoring map \(g:\mathcal Z\to \mathcal L\), and evaluator version \(v\). The rubric declares which labels count as success and which observations are abstentions.
Definition. A grader response law [ftip-00H3]AGENTDRAFTED
Definition. A grader response law [ftip-00H3]AGENTDRAFTED
For rubric \(R\), a grader response law is a kernel \(K(\ell \mid z)\) on \(\mathcal L\) given outcome \(z\). A deterministic grader is the point-mass case; stochastic or model-based graders must retain their version and sampling coordinates.
Definition. A calibration set [ftip-00H4]AGENTDRAFTED
Definition. A calibration set [ftip-00H4]AGENTDRAFTED
A calibration set is a finite set \(\mathcal C\subseteq \mathcal Z\) with an adjudicated label \(y^star(z)\) for each \(z\in \mathcal C\). The adjudication source, disagreement policy, and release version are part of the set’s provenance.
Definition. Calibration agreement [ftip-00H5]AGENTDRAFTED
Definition. Calibration agreement [ftip-00H5]AGENTDRAFTED
For grader kernel \(K\) and calibration set \(\mathcal C\), the agreement rate is \(A(K,\mathcal C)=|\mathcal C|^{-1}\sum _{z\in \mathcal C} K(y^star(z)\mid z)\). It is a calibration-set statistic, not a population accuracy claim.
Lemma. Agreement threshold admission [ftip-00H6]AGENTDRAFTED
Lemma. Agreement threshold admission [ftip-00H6]AGENTDRAFTED
If \(|\mathcal C|=n\geq 1\) and \(A(K,\mathcal C)\geq 1-\eta \), then the empirical disagreement mass \(1-A(K,\mathcal C)\) is at most \(\eta \).
Proof.
Proof.
Rearrange the defining finite average in Definition [ftip-00H5]. No generalization beyond \(\mathcal C\) is implied.
Example. High aggregate agreement can hide a subgroup failure [ftip-00H7]AGENTDRAFTED
Example. High aggregate agreement can hide a subgroup failure [ftip-00H7]AGENTDRAFTED
A grader that agrees on 99 of 100 easy cases but disagrees on the one safety case has overall agreement \(99/101\approx 0.9802\). Its agreement within the safety subgroup is zero. Any positive safety-subgroup agreement threshold therefore rejects this grader despite its high overall agreement. A calibration report stratifies by failure-relevant labels.
Definition. A grader release gate [ftip-00H8]AGENTDRAFTED
Definition. A grader release gate [ftip-00H8]AGENTDRAFTED
A grader release gate accepts \(K\) only when its calibration version, agreement thresholds, abstention handling, and stratified failure checks are recorded. A failed gate blocks interpretation of downstream score changes.
Remark. Scope of grading methodology [ftip-00H9]AGENTDRAFTED
Remark. Scope of grading methodology [ftip-00H9]AGENTDRAFTED
Part II of [jarmak2026reliable] organizes grading and reviewer calibration practices. The finite agreement quantities do not establish a universal threshold or blinded-human reliability theorem.
Execution gates and durable state [ftip-00HA]AGENTDRAFTED
Execution gates and durable state [ftip-00HA]AGENTDRAFTED
Definition. An execution gate [ftip-00HB]AGENTDRAFTED
Definition. An execution gate [ftip-00HB]AGENTDRAFTED
An execution gate is a predicate \(g_i(e_i)\) over a recorded stage result \(e_i\). It names its owner, required inputs, pass/fail/unknown outputs, and the artifact versions to which the result applies.
Definition. An ordered gate chain [ftip-00HC]AGENTDRAFTED
Definition. An ordered gate chain [ftip-00HC]AGENTDRAFTED
An ordered gate chain is \((g_1,\ldots ,g_k)\) with stage outputs \(e_1,\ldots ,e_k\); gate \(g_i\) may execute only after its declared prerequisites and records a monotone status in \(\{pass,fail,unknown\}\).
Theorem. A failed gate blocks a release conjunction [ftip-00HD]AGENTDRAFTED
Theorem. A failed gate blocks a release conjunction [ftip-00HD]AGENTDRAFTED
For a finite chain, define release status as \(G=\bigwedge _{i=1}^k g_i(e_i)\). If any gate is false, then \(G\) is false.
Proof.
Proof.
This is the defining conjunction of finitely many Boolean gate predicates. It says nothing about whether a later gate would have passed.
Definition. A durable execution record [ftip-00HE]AGENTDRAFTED
Definition. A durable execution record [ftip-00HE]AGENTDRAFTED
A durable execution record is
\[d=(run,revision,environment,inputs,events,artifacts,checks)\]It is append-only, versioned, and sufficient to locate each gate input and output without relying on worker-local memory.
Definition. A replay contract [ftip-00HF]AGENTDRAFTED
Definition. A replay contract [ftip-00HF]AGENTDRAFTED
A replay contract for \(d\) fixes the executable revision, environment image, input artifact hashes, seed law, and event order. A replay is faithful only when those coordinates are available and the resulting events satisfy the recorded schema.
Theorem. Deterministic replay reproduces a recorded trace [ftip-00HG]AGENTDRAFTED
Theorem. Deterministic replay reproduces a recorded trace [ftip-00HG]AGENTDRAFTED
If the execution map is deterministic in the coordinates fixed by Definition [ftip-00HF], replaying the same inputs, revision, environment, and seed produces the same event trace.
Proof.
Proof.
Induct over the finite event sequence. Equal initial coordinates give equal first events; determinism and equal prefixes give the next event.
Example. Replayability is not correctness [ftip-00HH]AGENTDRAFTED
Example. Replayability is not correctness [ftip-00HH]AGENTDRAFTED
A reproducible run can deterministically reproduce a wrong patch or a misconfigured evaluator. Replay establishes trace identity under its contract; it does not establish that the trace met the intended utility or safety goal.
Definition. A state-integrity digest [ftip-00HI]AGENTDRAFTED
Definition. A state-integrity digest [ftip-00HI]AGENTDRAFTED
For durable record \(d\), let \(H(d)\) be a cryptographic digest of its canonical serialized fields. A replay request fails closed when the supplied record digest or any referenced input hash differs from the declared value.
To bind a replay result to an audit decision, the replay trace must be included in the audited record and covered by its digest. A matching digest for other fields does not bind that trace to the decision.
Remark. Scope of execution methodology [ftip-00HJ]AGENTDRAFTED
Remark. Scope of execution methodology [ftip-00HJ]AGENTDRAFTED
Part III of [jarmak2026reliable] motivates containment, durable execution, and recovery records. Deterministic replay and matching digests establish execution consistency; they do not ensure correctness.
Audit before commit and failure taxonomy [ftip-00HK]AGENTDRAFTED
Audit before commit and failure taxonomy [ftip-00HK]AGENTDRAFTED
Definition. An audit-before-commit record [ftip-00HL]AGENTDRAFTED
Definition. An audit-before-commit record [ftip-00HL]AGENTDRAFTED
An audit-before-commit record is \(a=(d,scope,checks,reviewer,decision)\). It binds the durable execution record \(d\) to the audited scope, check list, review identity, and a decision in \(\{commit,hold,reject\}\).
Theorem. Audit-before-commit safety gate [ftip-00HM]AGENTDRAFTED
Theorem. Audit-before-commit safety gate [ftip-00HM]AGENTDRAFTED
A commit decision is admissible only if every required check in an Definition [ftip-00HL] record is pass, the audited digest equals the proposed record digest, and the decision is \(commit\).
Proof.
Proof.
Admissibility is defined as the conjunction of these three recorded conditions; failure of any conjunct yields hold or reject.
Definition. An independent audit scope [ftip-00HN]AGENTDRAFTED
Definition. An independent audit scope [ftip-00HN]AGENTDRAFTED
An audit is independent for scope \(S\) when its inputs are frozen before review, its reviewer or checker is distinct from the proposing action, and its decision cannot rewrite \(S\) without a new record. Independence is a protocol condition, not a claim of infallibility.
Example. A latent failure caught before commit [ftip-00HO]AGENTDRAFTED
Example. A latent failure caught before commit [ftip-00HO]AGENTDRAFTED
A run may pass unit tests while an independent audit finds that the evaluator version in \(d\) differs from the declared version. The audit holds the commit and records the mismatch; replay alone would not have caught it.
Definition. A reliability failure taxonomy [ftip-00HP]AGENTDRAFTED
Definition. A reliability failure taxonomy [ftip-00HP]AGENTDRAFTED
Classify a failed run by its earliest violated contract: measurement failure (M), grading failure (G), execution/state failure (E), audit failure (A), or transfer failure (T). A single run may receive secondary labels, but the primary label is the earliest failed gate in recorded order.
Lemma. Earliest-failure labels are unique [ftip-00HQ]AGENTDRAFTED
Lemma. Earliest-failure labels are unique [ftip-00HQ]AGENTDRAFTED
For a finite ordered gate chain with at least one failed gate, the earliest failed index is unique and therefore determines one primary taxonomy label.
Proof.
Proof.
Every nonempty finite subset of ordered indices has a unique least element.
Definition. A remediation record [ftip-00HR]AGENTDRAFTED
Definition. A remediation record [ftip-00HR]AGENTDRAFTED
A remediation record maps a primary label from Definition [ftip-00HP] to an owner, corrective action, re-test scope, and closure condition. Closure requires a new durable record and cannot mutate the failed record in place.
Remark. Scope of audit methodology [ftip-00HS]AGENTDRAFTED
Remark. Scope of audit methodology [ftip-00HS]AGENTDRAFTED
Parts III and V of [jarmak2026reliable] motivate durable execution, review, and accountability practices. The audit taxonomy and conjunction gates are proposed operational specifications; they do not establish that an audit is complete or that a committed artifact is correct.
Audit budgets and the scope of run-level evidence [ftip-00HT]AGENTDRAFTED
Audit budgets and the scope of run-level evidence [ftip-00HT]AGENTDRAFTED
Remark. A protocol is not a causal estimator [ftip-00HU]AGENTDRAFTED
Remark. A protocol is not a causal estimator [ftip-00HU]AGENTDRAFTED
The gates above make evidence auditable. They do not identify the causal effect of an intervention when task law, artifact, grader, budget, or harness state changes together. Those coordinates must be controlled in the matched evaluation of Definition [ftip-00GF].
Example. Counterexample: a perfect replay can repeat a contaminated result [ftip-00HV]AGENTDRAFTED
Example. Counterexample: a perfect replay can repeat a contaminated result [ftip-00HV]AGENTDRAFTED
Let a deterministic run train and evaluate on one leaked item. Its digest, event trace, and replay are all identical across reruns, yet the measurement is contaminated under Definition [ftip-00GV]. Replayability and contamination control are independent obligations.
Example. Counterexample: a calibrated grader can still face a changed domain [ftip-00HW]AGENTDRAFTED
Example. Counterexample: a calibrated grader can still face a changed domain [ftip-00HW]AGENTDRAFTED
A grader can meet its threshold on \(\mathcal C\) in Lemma [ftip-00H6] while every deployment item lies outside that calibration domain and receives an unvalidated label. Agreement on \(\mathcal C\) alone does not transport to a new law.
Theorem. Budgeted audit admission [ftip-00HX]AGENTDRAFTED
Theorem. Budgeted audit admission [ftip-00HX]AGENTDRAFTED
If an audit plan has finite nonnegative stage costs and its declared sum is at most budget \(B\), then the plan is budget-admissible; adding any positive stage beyond the remaining slack makes it inadmissible.
Proof.
Proof.
Apply additive cost monotonicity from Lemma [ftip-00GG].
Example. A cost-balanced audit plan [ftip-00HY]AGENTDRAFTED
Example. A cost-balanced audit plan [ftip-00HY]AGENTDRAFTED
With budget \(B=100\), a plan may allocate 50 units to execution, 30 to grading calibration, and 20 to audit. A proposed 10-unit extra audit must be funded by reducing another stage or the admission gate fails.
Remark. What this protocol can establish [ftip-00HZ]AGENTDRAFTED
Remark. What this protocol can establish [ftip-00HZ]AGENTDRAFTED
A passing protocol establishes that declared evidence contracts, hashes, checks, and budgets were satisfied for the recorded run. It does not establish capability acquisition, broad generalization, or absence of unobserved faults.
Evaluation, evidence, and finite limits [ftip-00JB]AGENTDRAFTED
Evaluation, evidence, and finite limits [ftip-00JB]AGENTDRAFTED
The training and agent mechanisms described earlier produce an artifact whose capability must be evaluated under a declared task law, inference procedure and resource account. This chapter fixes that comparison, studies what survives a change of evaluation, and examines discovery probabilities, support, proxy error and the information available through feedback.
Finite results and counterexamples establish consequences under specific probability laws and computational assumptions. They provide tools for the model-lineage question, where their assumptions must cover an evolving research and training process. The architecture analysis uses the same evaluation framework for comparisons that depend on a model implementation or optimizer.
Independent evaluation and post-training potential [ftip-005C]AGENTDRAFTED
Independent evaluation and post-training potential [ftip-005C]AGENTDRAFTED
A training score cannot by itself answer how much reliable capability was obtained. This section fixes an evaluation law, an inference procedure, and a resource account before comparing post-training protocols.
Convention. Fixed evaluation interface for protocol comparison [ftip-005D]AGENTDRAFTED
Convention. Fixed evaluation interface for protocol comparison [ftip-005D]AGENTDRAFTED
Fix an evaluation task \(\mathsf T_{\rm ev}\) from Definition [ftip-001O] and a measurable scalar evaluation utility \(u_{\mathsf T_{\rm ev}}:\mathcal X_{\mathsf T_{\rm ev}}\times \mathcal O_{\mathsf T_{\rm ev}}\times \Omega _E\to \mathbb R\), the \(d=1\) case of Definition [ftip-001T]. Fix its task law \(Q_{\rm ev}:=\mu _{\mathsf T_{\rm ev}}\), an inference protocol \(\mathsf I_{\rm ev}\) from Definition [ftip-001R], and an inference budget \(b\in \mathcal B_{\mathrm {eval}}\). Use the inference-seed space \(\Omega _I\) and evaluator-seed space \(\Omega _E\) from Notation [ftip-001N]. A declared probability kernel on these measurable spaces \(\Lambda _{\rm ev}(d\xi ,d\omega \mid x)\) assigns inference and evaluator randomness to each instance. Together with \(Q_{\rm ev}\), it gives the joint evaluation law \(\nu _{\rm ev}(dx,d\xi ,d\omega ) =Q_{\rm ev}(dx)\Lambda _{\rm ev}(d\xi ,d\omega \mid x)\), which is fixed independently of training.
Declare a measurable space \(\mathcal M\) of executable artifacts. For \(M\in \mathcal M\), define the aliases \[ \mathsf {Eval}_b(M,x;\xi ) :=\operatorname {pr}_1\left (\mathsf I_{\rm ev}(M,x,b;\xi )\right ), \qquad U(x,o;\omega ):=u_{\mathsf T_{\rm ev}}(x,o;\omega ). \] Require \(\mathsf {Eval}_b\) to be measurable in \((M,x,\xi )\) and to return admissible outcomes on admitted runs.
Each post-training protocol \(P\) has a probability space \((\Omega _P,\Sigma _P,\mathbb P_P)\) for its randomness and a measurable artifact map \(M_P:\Omega _P\to \mathcal M\) produced from the common base artifact \(M_0\). The no-training protocol is \(P_0\). The complete evaluation law for \(P\) is the product \(\mathbb P_P\otimes \nu _{\rm ev}\), expressing independence between protocol randomness and the fixed evaluation draw. For \(\zeta \in \Omega _P\), write \[ Z_P(\zeta ,x,\xi ,\omega ) =U\left (x,\mathsf {Eval}_b(M_P(\zeta ),x;\xi );\omega \right ). \] This composite is measurable. Every protocol compared through expected performance, including the baseline \(P_0\), must satisfy \[ \int |Z_P|\,d(\mathbb P_P\otimes \nu _{\rm ev})<\infty . \] This is the evaluation domain; finite pointwise utility does not replace the absolute-integrability condition. Fix also a scalar success threshold \(u_*\in \mathbb R\).
Definition. Expected evaluation performance [ftip-005E]AGENTDRAFTED
Definition. Expected evaluation performance [ftip-005E]AGENTDRAFTED
For a protocol \(P\) in the integrable evaluation domain of Convention [ftip-005D], its expected evaluation performance is the finite real number
\[ \begin {aligned} J_{\rm ev}(P) &=\int Z_P\,d(\mathbb P_P\otimes \nu _{\rm ev}),\\ &=\mathbb E\left [ U\left (X,\mathsf {Eval}_b(M_P,X;\Xi );\Omega \right ) \right ], \\ (X,\Xi ,\Omega )&\sim Q_{\rm ev}(dx)\Lambda _{\rm ev}(d\xi ,d\omega \mid x). \end {aligned} \]The label \(\rm ev\) abbreviates the task, law, inference protocol, budget, utility, and seed law fixed above. Changing any of them changes the estimand. Both positive and negative parts of \(Z_P\) have finite expectation; an undefined expectation or an infinite value is outside this real-valued performance domain.
Definition. Post-training gain [ftip-005F]AGENTDRAFTED
Definition. Post-training gain [ftip-005F]AGENTDRAFTED
For \(P\) and the no-training protocol \(P_0\) both satisfying the absolute-integrability condition of Convention [ftip-005D], the post-training gain is the real-valued difference
\[ \Delta J_{\rm ev}(P) =J_{\rm ev}(P)-J_{\rm ev}(P_0). \]Both terms use the same evaluator, task law, utility, and inference budget. The subtraction does not compare different model families or evaluation procedures. In particular, \(+\infty -(+\infty )\) is not an admitted gain.
Remark. Evaluation gain under a fixed task law [ftip-005G]AGENTDRAFTED
Remark. Evaluation gain under a fixed task law [ftip-005G]AGENTDRAFTED
The policy-evaluation expectation of Section 3.5 of Reinforcement learning: An introduction[sutton2018reinforcement] specializes to an independently fixed task law and inference procedure. The gain is a paired contrast with the same base artifact and evaluator.
A positive value shows a change under this evaluation. It does not alone show that the trained policy acquired a capability under the criterion of Definition [ftip-0007].
Definition. Lifecycle cost vector [ftip-005H]AGENTDRAFTED
Definition. Lifecycle cost vector [ftip-005H]AGENTDRAFTED
The realized lifecycle cost vector of a protocol is the random vector \(C(P)\in \mathbb R_+^7\), measurable on its declared lifecycle-run probability space, that records separately
\[ C(P)= (C_{\rm data},C_{\rm feedback},C_{\rm rollout},C_{\rm env}, C_{\rm update},C_{\rm storage},C_{\rm eval}). \]A componentwise lifecycle budget is a vector \(\mathbf B\in \mathbb R_+^7\). Each cost coordinate has a declared unit, such as tokens, labels, accelerator floating-point operations (FLOPs), sandbox time, bytes, or evaluator calls. A scalar price may be applied later, but the typed vector is retained. Each nonnegative coordinate has a well-defined expectation in \([0,+\infty ]\); finite realized costs need not have finite expectations. A finite componentwise budget excludes protocols with any infinite expected-cost coordinate. When costs include the fixed independent evaluation draw, the run law may include the product law in Convention [ftip-005D]; the accounting record must specify which randomness is averaged.
Remark. Lifecycle costs have distinct units [ftip-005I]AGENTDRAFTED
Remark. Lifecycle costs have distinct units [ftip-005I]AGENTDRAFTED
The scaling study behind Definition [ftip-001C] reports training tokens and compute separately.
[hoffmann2022training, sec. 3] studies their allocation. Training tokens and compute are therefore separate cost coordinates.
Agentic and replay protocols also incur verifier, environment, storage, and selection work. A training step, a generated rollout, and one second of wall time are therefore different units.
The vector permits later cost models without hiding which conversion rates or hardware assumptions they use.
Definition. Admissible protocol class [ftip-005J]AGENTDRAFTED
Definition. Admissible protocol class [ftip-005J]AGENTDRAFTED
For a base artifact \(M_0\), an admissible protocol class \(\mathfrak P(M_0)\) is a declared set of type-correct training procedures. Membership fixes which data sources, feedback channels, model changes, environment interfaces, and update rules are permitted. For the expected performance comparison, every member also satisfies the measurable generation and integrable evaluation domain of Convention [ftip-005D], and carries the measurable nonnegative cost vector of Definition [ftip-005H]. The baseline \(P_0\) must satisfy the evaluation domain even if it is not feasible at the chosen cost budget.
The class is part of the research question. Enlarging it can only enlarge the set of attainable outcomes, but may make a comparison less informative.
Definition. Trust contract [ftip-005K]AGENTDRAFTED
Definition. Trust contract [ftip-005K]AGENTDRAFTED
A trust contract \(\mathsf {Trust}(P)\) is a predicate requiring the protocol to respect declared provenance, information, and accounting boundaries. At minimum it specifies evaluation independence, behavior-policy stamps for reused rollouts, environment and verifier versions, and complete lifecycle-cost reporting.
The predicate is evidence to be checked. It is not a statement that a protocol is safe, aligned, or free from distribution shift.
Remark. Allowed procedures and admissible evidence [ftip-005L]AGENTDRAFTED
Remark. Allowed procedures and admissible evidence [ftip-005L]AGENTDRAFTED
The protocol class and trust contract impose distinct restrictions. The class states what may be attempted; the contract states what evidence an attempt must retain before it can enter the comparison.
Their joint specification is a proposed evaluation framework.
A supremum over an unspecified class or an unaudited evaluation boundary has no stable empirical interpretation.
Definition. Costed post-training potential [ftip-005M]AGENTDRAFTED
Definition. Costed post-training potential [ftip-005M]AGENTDRAFTED
For a scalar evaluation utility, the costed post-training potential of \(M_0\) under a finite componentwise budget \(\mathbf B\in \mathbb R_+^7\) is the extended-real supremum
\[ \Phi (M_0,\mathbf B) =\sup _{P\in \mathfrak P(M_0)} \left \{ J_{\rm ev}(P): \mathsf {Trust}(P),\ \mathbb E[C(P)]\leq \mathbf B \right \}. \]Here \(\mathfrak P(M_0)\) has the evaluation domain of Definition [ftip-005J], so each \(J_{\rm ev}(P)\) is real. The expected-cost inequality is componentwise in \([0,+\infty ]^7\); it cannot hold against a finite budget if any coordinate is infinite. Define \(\sup \varnothing =-\infty \), and use \(+\infty \) when feasible performance values are unbounded above. Thus \(\Phi \) takes values in \(\overline {\mathbb R}=\mathbb R\cup \{-\infty ,+\infty \}\).
The potential is finite real exactly when its feasible performance set is nonempty and bounded above. For example, a common finite upper bound on utility and at least one feasible protocol suffice. This does not guarantee that any protocol attains the supremum. Ordinary differences, ratios, or derivatives of potential values require finite real operands and any further regularity hypotheses needed by that operation. The value is conditional on every object named in the display; it is not an intrinsic constant of the model.
Remark. Potential depends on the intervention and budget [ftip-005N]AGENTDRAFTED
Remark. Potential depends on the intervention and budget [ftip-005N]AGENTDRAFTED
The potential \(\Phi \) describes how evaluation performance varies with the base artifact, admissible information, protocol family, and resource budget. The definition supplies no scaling exponent and no guarantee that a maximizing protocol exists.
Empirical studies provide conditional points or bounds only after their protocol, evaluator, and costs are embedded in this interface. An observed benchmark maximum need not equal a universal ceiling.
Definition. feasible objective set [boyd2004convex, Section 4.7.4] [ftip-005O]AGENTDRAFTED
Definition. feasible objective set [boyd2004convex, Section 4.7.4] [ftip-005O]AGENTDRAFTED
For a multi-objective optimization problem with vector objective \(f(x)\), the feasible objective set is the collection of vectors \(f(x)\) attained by feasible choices \(x\).
In a post-training application, the feasible choice is a trusted, budget-feasible protocol and the objective vector contains independently declared evaluation outcomes.
Definition. weighted-sum scalarization [boyd2004convex, Section 4.7.5] [ftip-005P]AGENTDRAFTED
Definition. weighted-sum scalarization [boyd2004convex, Section 4.7.5] [ftip-005P]AGENTDRAFTED
For objective vector \(v\in \mathbb R^m\) and nonnegative weights \(w\in \mathbb R_+^m\), the weighted-sum scalarization assigns the score \(w^\top v\). Optimizing this score selects a point according to the declared weights.
Changing \(w\) changes the research question. A single weighted score can hide tradeoffs among evaluation groups or task families.
Definition. Pareto-optimal objective vector [boyd2004convex, Section 4.7.4] [ftip-005Q]AGENTDRAFTED
Definition. Pareto-optimal objective vector [boyd2004convex, Section 4.7.4] [ftip-005Q]AGENTDRAFTED
A feasible vector \(v\) is Pareto optimal when there is no feasible \(v'\) with \(v'_j\geq v_j\) in every coordinate and a strict inequality in at least one coordinate. The Pareto frontier is the set of such vectors.
This order preserves visible tradeoffs. It does not choose one point on the frontier.
Definition. worst-group risk [sagawa2020distributionally, Section 2] [ftip-005R]AGENTDRAFTED
Definition. worst-group risk [sagawa2020distributionally, Section 2] [ftip-005R]AGENTDRAFTED
Given predefined groups with risks \(L_g\), the worst-group risk is \(\max _g L_g\). For utilities, the corresponding robust score is \(\min _g J_g\).
A post-training comparison must declare the groups and their evaluation laws before using this score. It is different from an average and from Pareto dominance.
Example. Three attainable protocols with different scalar, Pareto, and worst-group summaries [ftip-005S]AGENTDRAFTED
Example. Three attainable protocols with different scalar, Pareto, and worst-group summaries [ftip-005S]AGENTDRAFTED
Three attainable utility vectors separate the answers returned by scalarization, Pareto comparison, and a worst-group summary.
For scalar weights \((0.8,0.2)\), the scores are \(S(A)=0.80\), \(S(B)=0.70\), and \(S(C)=0.56\), so \(A\) wins. The worst-group scores are \(0.4\), \(0.7\), and \(0.5\), so \(B\) wins. No point dominates another coordinatewise, hence the Pareto summary retains all three.
The scalar, Pareto, and worst-group summaries were defined in Definition [ftip-005P]--Definition [ftip-005R]. Their non-equivalence is explicit in these three points, while the choice of a social or evaluation rule remains open.
Evaluation transport and matched protocols [ftip-00F9]AGENTDRAFTED
Evaluation transport and matched protocols [ftip-00F9]AGENTDRAFTED
This section compares post-training artifacts only through declared evaluation laws, inference protocols, utilities, seeds, and budgets. It proves finite transport statements locally and treats long-horizon research-state records as empirical evidence, not as theorems.
Evaluation laws and couplings [ftip-00FA]AGENTDRAFTED
Evaluation laws and couplings [ftip-00FA]AGENTDRAFTED
Convention. A named evaluation experiment [ftip-00FB]AGENTDRAFTED
Convention. A named evaluation experiment [ftip-00FB]AGENTDRAFTED
A named evaluation experiment records the artifact, task law, inference protocol, evaluator, seed kernel, budget, and sampling unit. Two reported scores are comparable only after these coordinates and their intended target have been stated.
Definition. Evaluation law [ftip-00FC]AGENTDRAFTED
Definition. Evaluation law [ftip-00FC]AGENTDRAFTED
For a fixed evaluation interface from Convention [ftip-005D], an evaluation law is a probability measure \(\mathsf Q\) on the finite outcome space \(\mathcal Z=\mathcal X_{\mathsf T_{\rm ev}}\times \mathcal O_{\mathsf T_{\rm ev}}\) with random pair \((X,O)\sim \mathsf Q\). Its score for artifact \(M\) is a bounded measurable map \(s_M:\mathcal Z\to [0,1]\). Write \(J_{\mathsf Q}(M)=\mathbb E_{\mathsf Q}[s_M(X,O)]\).
Definition. Matched evaluation pair [ftip-00FD]AGENTDRAFTED
Definition. Matched evaluation pair [ftip-00FD]AGENTDRAFTED
A matched evaluation pair is \((\mathsf Q,\mathsf I,b,\Lambda )\) and \((\mathsf Q',\mathsf I',b',\Lambda ')\) together with a coupling \((Z,Z')\) whose marginals are the two laws. The pair is matched on the declared coordinates when the task, utility, evaluator version, and sampling unit are shared; any changed coordinate is named.
Definition. Paired finite score estimator [ftip-00FE]AGENTDRAFTED
Definition. Paired finite score estimator [ftip-00FE]AGENTDRAFTED
For iid coupled draws \((Z_j,Z'_j)_{j=1}^m\), define \(\widehat \Delta _m=m^{-1}\sum _{j=1}^m(s_M(Z_j)-s_{M'}(Z'_j))\). The pairing is part of the estimator specification; it does not silently identify the two evaluation laws.
Theorem. Unbiasedness of the paired score estimator [ftip-00FF]AGENTDRAFTED
Theorem. Unbiasedness of the paired score estimator [ftip-00FF]AGENTDRAFTED
Under the iid coupling in Definition [ftip-00FE], \(\mathbb E[\widehat \Delta _m]=J_{\mathsf Q}(M)-J_{\mathsf Q'}(M')\).
Proof.
Proof.
Linearity of expectation gives the displayed identity.
\[ \mathbb E[\widehat \Delta _m] =m^{-1}\sum _j\left (\mathbb E[s_M(Z_j)]- \mathbb E[s_{M'}(Z'_j)]\right ). \]The coupling fixes the joint sampling but does not change either marginal, so the two terms are the stated expectations.
Example. Common seeds can reduce paired variance [ftip-00G0]AGENTDRAFTED
Example. Common seeds can reduce paired variance [ftip-00G0]AGENTDRAFTED
If \(s_M(Z)=s_{M'}(Z')\) almost surely under a common-seed coupling, then \(\widehat \Delta _m=0\) for every sample even when independent sampling would have nonzero variance. This is a variance statement, not evidence that the two artifacts have equal behavior on a different law.
Remark. A coupling does not merge estimands [ftip-00G1]AGENTDRAFTED
Remark. A coupling does not merge estimands [ftip-00G1]AGENTDRAFTED
The result in Theorem [ftip-00FF] follows from its displayed hypotheses. A shared seed can make a paired comparison precise while the changed task law, evaluator, or inference budget still changes the estimand. No causal effect follows without a declared intervention and matched coordinates.
Utility transport [ftip-00G2]AGENTDRAFTED
Utility transport [ftip-00G2]AGENTDRAFTED
Definition. Bounded utility perturbation [ftip-00G3]AGENTDRAFTED
Definition. Bounded utility perturbation [ftip-00G3]AGENTDRAFTED
On a common finite outcome law \(\mathsf Q\), let each artifact \(M\) have score maps \(s_M,t_M:\mathcal Z\to [0,1]\). They have perturbation radius \(\varepsilon =\sup _{M,\,z\in \operatorname {supp}(\mathsf Q)} |s_M(z)-t_M(z)|\) when \(0\leq \varepsilon \leq 1\); write \(J_s(M)=\mathbb E_{\mathsf Q}[s_M]\) and \(J_t(M)=\mathbb E_{\mathsf Q}[t_M]\).
Theorem. Direct utility transport bound [ftip-00G4]AGENTDRAFTED
Theorem. Direct utility transport bound [ftip-00G4]AGENTDRAFTED
Under Definition [ftip-00G3], every artifact \(M\) satisfies \(|J_s(M)-J_t(M)|\leq \varepsilon \).
Proof.
Proof.
Pointwise bounds give \(-\varepsilon \leq s_M(z)-t_M(z)\leq \varepsilon \). Taking expectations preserves both inequalities.
Corollary. Transporting an artifact comparison [ftip-00G5]AGENTDRAFTED
Corollary. Transporting an artifact comparison [ftip-00G5]AGENTDRAFTED
If two artifacts \(M_1,M_0\) are scored by both \(s\) and \(t\) under the same law and \(\lVert s-t\rVert _{\infty ,\mathsf Q}\leq \varepsilon \), then the gain difference obeys \(|(J_s(M_1)-J_s(M_0))-(J_t(M_1)-J_t(M_0))| \leq 2\varepsilon \). This is a finite utility perturbation bound, not a training or distribution-shift theorem.
Example. Equal aggregate score can hide a slice reversal [ftip-00G6]AGENTDRAFTED
Example. Equal aggregate score can hide a slice reversal [ftip-00G6]AGENTDRAFTED
On equally likely outcomes \(a,b\), take score vectors \((s_{M_1}(a),s_{M_1}(b))=(1,0)\) and \((s_{M_0}(a),s_{M_0}(b))=(0,1)\); a second score map swaps coordinates. Both artifacts have aggregate score \(1/2\) under both maps, but their per-outcome ordering reverses. Aggregate transport alone does not identify localized behavior.
Remark. Common domains are a transport hypothesis [ftip-00G7]AGENTDRAFTED
Remark. Common domains are a transport hypothesis [ftip-00G7]AGENTDRAFTED
The bound in Theorem [ftip-00G4] requires the same finite outcome support. Changing prompts, parsers, evaluators, or inference budgets is a new law and must be recorded rather than hidden inside a score perturbation.
Prompt and research-state transport [ftip-00G8]AGENTDRAFTED
Prompt and research-state transport [ftip-00G8]AGENTDRAFTED
Definition. Research-state observable [ftip-00G9]AGENTDRAFTED
Definition. Research-state observable [ftip-00G9]AGENTDRAFTED
For a finite record space \(\mathcal R\), an observable is a map \(h:\mathcal R\to \mathcal H\). A summary-only evaluator sees \(h(r)\) and not the underlying record \(r\); the omitted coordinates are unavailable to that evaluator.
Definition. Compaction kernel [ftip-00GA]AGENTDRAFTED
Definition. Compaction kernel [ftip-00GA]AGENTDRAFTED
A compaction kernel is a randomized map \(K(dh\mid r)\) from records in \(\mathcal R\) to summaries in \(\mathcal H\). A deterministic summary is the special case \(K(dh\mid r)=\delta _{h(r)}\).
Theorem. Summary-only indistinguishability [ftip-00GB]AGENTDRAFTED
Theorem. Summary-only indistinguishability [ftip-00GB]AGENTDRAFTED
Let \(r,r'\in \mathcal R\) induce the same summary law under the kernel in Definition [ftip-00GA]. Any randomized decision rule that receives only that summary has the same output law in the two worlds.
Proof.
Proof.
The output law is the pushforward of the common summary law through the same decision kernel. Pushforwards of equal finite measures are equal.
Example. An omitted feasibility constraint [ftip-00GC]AGENTDRAFTED
Example. An omitted feasibility constraint [ftip-00GC]AGENTDRAFTED
Two research records can share every summary score while one contains a withdrawn lemma and the other contains a feasible proof plan. A summary-only selector therefore chooses identically, although the correct next action differs. This is a finite witness to information loss, not a claim about a particular model.
Remark. Long-horizon records are empirical transport evidence [ftip-00GD]AGENTDRAFTED
Remark. Long-horizon records are empirical transport evidence [ftip-00GD]AGENTDRAFTED
The case study in [li2026longhorizon], Sections 4--7, reports file-based memory, human steering, and research-state failures under one system and task. It motivates explicit observables and omitted constraints; it does not supply the finite theorem in Theorem [ftip-00GB] or a general model capability law.
Evaluation cells and budget accounting [ftip-00GE]AGENTDRAFTED
Evaluation cells and budget accounting [ftip-00GE]AGENTDRAFTED
Definition. Evaluation cell [ftip-00GF]AGENTDRAFTED
Definition. Evaluation cell [ftip-00GF]AGENTDRAFTED
An evaluation cell is \(C=(M,\mathsf Q,\mathsf I,b,\Lambda ,v)\), where \(M\) is an artifact, \(\mathsf Q\) a task law, \(\mathsf I\) an inference protocol, \(b\) a budget, \(\Lambda \) a seed kernel, and \(v\) an evaluator version. A cell comparison may differ in named coordinates only.
Lemma. Additive evaluation cost [ftip-00GG]AGENTDRAFTED
Lemma. Additive evaluation cost [ftip-00GG]AGENTDRAFTED
For a finite evaluation plan with disjoint stages of costs \(c_1,\ldots ,c_k\in \mathbb R_{\geq 0}\), total cost is \(c=\sum _{i=1}^k c_i\). Appending a stage increases cost by its declared amount and cannot preserve a budget \(B\) unless the remaining slack covers it.
Proof.
Proof.
The statement is the associativity and monotonicity of finite sums.
Theorem. Budget-preserving matched comparison [ftip-00GH]AGENTDRAFTED
Theorem. Budget-preserving matched comparison [ftip-00GH]AGENTDRAFTED
Let two evaluation plans use the same declared stages except for a substitution whose cost is at most the replaced stage cost. If their common prefix cost is \(c_0\) and both suffix costs fit \(B-c_0\), then both cells in Definition [ftip-00GF] are admissible under budget \(B\).
Proof.
Proof.
Apply Lemma [ftip-00GG] to the common prefix and each suffix. The assumed inequalities give total cost at most \(B\) in each plan.
Example. Cost-balanced evaluation cells [ftip-00GI]AGENTDRAFTED
Example. Cost-balanced evaluation cells [ftip-00GI]AGENTDRAFTED
A paired run can spend \(B=100\) units as 40 units of inference, 20 of evaluator calls, and 40 of audit. Replacing 10 inference units by 10 audit units preserves the budget, but changes the cell and must not be described as the same inference protocol.
Remark. Execution and evaluator confounds [ftip-00GJ]AGENTDRAFTED
Remark. Execution and evaluator confounds [ftip-00GJ]AGENTDRAFTED
A score change can arise from the artifact, prompt law, inference budget, parser, evaluator version, or execution failure. A matched-cell report names these coordinates before interpreting a paired gain.
Distribution shift and ranking reversals [ftip-00GK]AGENTDRAFTED
Distribution shift and ranking reversals [ftip-00GK]AGENTDRAFTED
Example. Train and evaluation laws can reverse a ranking [ftip-00GL]AGENTDRAFTED
Example. Train and evaluation laws can reverse a ranking [ftip-00GL]AGENTDRAFTED
Let \(\mathsf Q_{\rm tr}\) put masses \(.9,.1\) on \(a,b\), and let \(\mathsf Q_{\rm ev}\) swap them. Artifacts \(M_1,M_0\) with score vectors \((s_{M_1}(a),s_{M_1}(b))=(1,0)\) and \((s_{M_0}(a),s_{M_0}(b))=(0,1)\) rank oppositely under the two laws. A training score is not an evaluation transport certificate.
Theorem. Total-variation transport bound [ftip-00GM]AGENTDRAFTED
Theorem. Total-variation transport bound [ftip-00GM]AGENTDRAFTED
For any score \(s:\mathcal Z\to [0,1]\) and finite laws \(\mathsf Q,\mathsf Q'\), \(|\mathbb E_{\mathsf Q}s-\mathbb E_{\mathsf Q'}s|\leq \lVert \mathsf Q-\mathsf Q'\rVert _{\rm TV}\), where \(\lVert \mathsf Q-\mathsf Q'\rVert _{\rm TV}:=\frac 12\sum _{z\in \mathcal Z} |\mathsf Q(z)-\mathsf Q'(z)|\).
Proof.
Proof.
Expand the finite expectation difference and use \(|s(z)|\leq 1\). The positive and negative parts are bounded by the total variation mass, giving the displayed inequality.
Example. A sharp two-point transport bound [ftip-00GN]AGENTDRAFTED
Example. A sharp two-point transport bound [ftip-00GN]AGENTDRAFTED
On \(\mathcal Z=\{a,b\}\), let \(s(a)=1,s(b)=0\), and let \(\mathsf Q(a)=1\), \(\mathsf Q'(a)=1-\eta \), and \(\mathsf Q'(b)=\eta \). The score difference and total variation distance are both \(\eta \).
Remark. What transport does not identify [ftip-00GO]AGENTDRAFTED
Remark. What transport does not identify [ftip-00GO]AGENTDRAFTED
The bounds above transport a declared score across a declared law. They do not identify why an artifact changed, establish support expansion, prove generalization, or order different evaluators whose outcome spaces differ.
Example. A minimal evaluation trace [ftip-00GP]AGENTDRAFTED
Example. A minimal evaluation trace [ftip-00GP]AGENTDRAFTED
A reproducible record is \((M,\mathsf Q,\mathsf I,b,\Lambda ,v,m, \widehat \Delta _m,c)\), listing the cells, sample count, paired estimate, and cost. Replaying this tuple reproduces the estimator target only when the recorded laws and versions remain available.
Remark. Execution controls for a matched evaluation [ftip-00GQ]AGENTDRAFTED
Remark. Execution controls for a matched evaluation [ftip-00GQ]AGENTDRAFTED
A matched evaluation requires execution gates, contamination checks, grader calibration, and an audit of the result before it is committed. These controls make the comparison auditable; they do not by themselves establish capability acquisition.
Sampling claims become comparable only when the task law, action serializer, verifier, and replay certificate are fixed together; § [ftip-00OW] gives that boundary.
Sampling and replay protocol [ftip-00OW]AGENTDRAFTED
Sampling and replay protocol [ftip-00OW]AGENTDRAFTED
A sampling comparison begins with a task interface and an evaluation inference protocol. Fix the task law from Notation [ftip-001N], the inference budget, the model artifact, the prompt and tokenizer, and the serializer \(S\) that maps a public history to a token or tool action. Let an intervention \(I\) change only the named sampler, random source, harness state, or evaluator coordinate; every other coordinate is held fixed. The four readouts below keep distribution fit, action behavior, verification, and replay evidence distinct.
Protocol estimands. For a declared finite output set \(\mathcal Y\), target law \(P^*\in \mathsf {Prob}(\mathcal Y)\), sample size \(n\geq 1\), and realized outputs \(Y_1,\ldots ,Y_n\in \mathcal Y\), define the target-distribution fit readout by
\[ \widehat P_{I,n}(y)=\frac 1n\sum _{j=1}^{n}{\bf 1}\{Y_j=y\},\qquad E_{\rm dist}(I)=d(\widehat P_{I,n},P^*), \]where \(d\) is a declared divergence or goodness-of-fit functional on \(\mathsf {Prob}(\mathcal Y)\). The task law, output serializer, sample size and random-source law are part of the intervention record; logits alone do not determine this readout.
For horizon \(T\geq 1\), public histories \(H_t\in \mathcal H_t\), and serialized actions \(A_t\in \mathcal A_t\), the action-law readout is the empirical measure
\[ \widehat \Pi _{I,n}=\frac 1n\sum _{j=1}^{n}\delta _{(H_{j,0},A_{j,0},\ldots ,H_{j,T-1},A_{j,T-1})}. \]The non-anticipating policy contract in Definition [ftip-0023] supplies the admissible action kernels and requires the serializer to be declared. Thus \(\widehat \Pi _{I,n}\) records what the system did on the declared histories; it does not establish that those actions follow \(P^*\).
For the evaluation utility and joint evaluation law \(\nu _I\) induced by the fixed task law, protocol randomness, inference seed, and evaluator seed, define the verifier readout by
\[ E_{\rm ver}(I)=\int u_{\mathsf T}(x,o;\omega )\,d\nu _I(x,o,\omega ). \]A binary verifier is the special case of the indicator in Definition [ftip-0046]; its version and evidence record follow Definition [ftip-0047]. The expectation is taken only when the measurability and integrability conditions of Definition [ftip-001T] and Convention [ftip-005D] hold. A successful check does not identify which sampler or harness state produced its trajectory.
Replay is evidence rather than a fourth scalar estimand. A replay certificate is the tuple
\[ \mathcal R_I=(M,x,S,Q_I,\nu _I,\rho _I,h_0,L_n,\boldsymbol v,(F_v)_v,\nu _{\rm pol},e_{\rm ver},C(I)), \]where \(\rho _I\) is the realized random-source state and \(L_n\) is the persistent event stream, \(h_0\), \(\boldsymbol v\) and \(F_v\) give the materialized harness state, \(\nu _{\rm pol}\) is the content-addressed policy stamp from Definition [ftip-004Z], \(e_{\rm ver}\) is verifier evidence from Definition [ftip-0047], and \(C(I)\) is the lifecycle cost vector. Equality of all these fields, including the task instance, model, sampler, serializer and policy stamp carried by the certificate or its event record, is the replay identity. The theorem in Theorem [ftip-00C9] then gives equal materialized state; replay identity still does not imply correctness, as Example [ftip-00HH] records.
Protocol proposal. The transition boundary is typed by the following finite sequence. The protocol computes logits from the model, task input and current public history; the sampler \(Q_I\) consumes those logits and random source \(\rho _I\) to produce \(A_t\); the event constructor records \(e_t=\operatorname {event}(H_t,A_t)\) and the public-history observer records \(H_{t+1}=\operatorname {observe}(H_t,e_t)\); the harness appends the same event and folds it:
\[ L_{t+1}=\operatorname {append}(L_t,e_t),\qquad H_{t+1}=\operatorname {observe}(H_t,e_t),\qquad h_{t+1}=F_{v_t}(h_t,e_t),\qquad (o,c)=\mathsf I(M,x,b;\xi ). \]The evaluator consumes the completed outcome and its evidence, not the pre-verification token. An intervention must name the changed member of \((M,x,S,Q_I,\rho _I,h_0,\boldsymbol v,e_{\rm ver})\) and the held-fixed members. A state update, retry, or evaluator call is a new event and contributes to the recorded lifecycle cost vector; these are not silently absorbed into the model effect.
Source observation. Gu et al. (arXiv:2604.06543v2, PDF pp. 4-10) find biased direct sampling and reliable seed-to-distribution transformations in the tested models ([gu2026stochasticity, Sections 3, 5, and 6]). H1 reports a simple Lean loop whose interface, verifier feedback, and self-reflection support a formal-Lean comparison (submitted 30 September 2026, PDF pp. 2-3 and 8-11; [moalla2026h1, Sections 2.1-2.2 and 4]); its reported benchmark results use additional empirical sections ([moalla2026h1, Sections 3.1-3.3]). Stateless Language Agents assign persistent experiment state to the harness while Advisor and Worker calls are stateless (arXiv:2610.07625v1, PDF pp. 3-12; [zhang2026statelessagents, Sections 2.2, 3.1-3.2, and 4.2-4.3]).
FTIP deduction. These observations justify separating the model, serializer, sampler, random source, harness, verifier, and lifecycle ledger. The empirical protocol itself has no corresponding Lean declaration in the searched Forest, formal-math, TauCetiReview, or TauCetiWorker revisions; Theorem [ftip-00C9] supports only the deterministic event-folding sub-result.
Finite replay check. Take \(\mathcal A_0=\{0,1\}\), horizon \(T=2\), \(h_0=()\), and events \(e_0=\operatorname {call}(0)\) and \(e_1=\operatorname {verify}(1)\). Let \(F(h,e)=h\mathbin {\|}e\) and \(L_2=(e_0,e_1)\). Two runs with the same policy stamp, realized random-source state, verifier identity, event version, fold map and cost vector have the same \(\mathcal R_I\); the recursion in Theorem [ftip-00C9] checks \(h_2=((\operatorname {call}(0)), (\operatorname {verify}(1)))\). Changing the recorded random-source state therefore fails the replay-identity check, even if a coincidentally identical event stream is produced. This finite certificate is the Phase A boundary: it makes replay auditable without claiming a universal stochasticity law.
Analytical questions and falsifiers [ftip-005T]AGENTDRAFTED
Analytical questions and falsifiers [ftip-005T]AGENTDRAFTED
Successful support, verifier error, and entropy statistics distinguish properties that a benchmark summary can combine. Finite examples and counterexamples distinguish these quantities.
Definition. Successful-support probability [ftip-005U]AGENTDRAFTED
Definition. Successful-support probability [ftip-005U]AGENTDRAFTED
Fix the evaluation interface and success threshold \(u_*\) from Convention [ftip-005D]. For a protocol \(P\) and instance \(x\in \mathcal X_{\mathsf T_{\rm ev}}\), its successful-support probability is
\[ p_P(x) =\Pr \left [ U\left (x,\mathsf {Eval}_b(M_P,x;\Xi );\Omega \right )\geq u_* \right ]. \]The probability includes protocol, inference, environment, and evaluator randomness: \(M_P\) is drawn from the protocol, while \((\Xi ,\Omega )\) is drawn from \(\Lambda _{\rm ev}(\cdot \mid x)\) independently of training. The quantity is instance-specific and budget-specific.
Definition. Successful-support coverage [ftip-005V]AGENTDRAFTED
Definition. Successful-support coverage [ftip-005V]AGENTDRAFTED
For threshold \(0<\alpha \leq 1\), the successful-support coverage of protocol \(P\) under evaluation law \(Q_{\rm ev}\) is
\[ \operatorname {Cov}_\alpha (P) =Q_{\rm ev}\left (\{x:p_P(x)\geq \alpha \}\right ). \]Coverage records how much task mass has at least the declared success probability. It does not average the probabilities above or below the threshold.
Remark. Task-level success and coverage [ftip-005W]AGENTDRAFTED
Remark. Task-level success and coverage [ftip-005W]AGENTDRAFTED
Increasing probability mass on known solutions need not increase coverage of the task family. Pass-at-\(k\) and related support-sensitive measurements motivate this distinction. Sections 3--5 of Does reinforcement learning really incentivize reasoning capacity in LLMs beyond the base model?[yue2025does] and Sections 2--3 of Understanding r1-zero-like training: A critical perspective[liu2025understanding] compare post-training behavior with base-model support and discuss why response accuracy alone may overstate what RL creates beyond a base model.
The threshold \(\alpha \), inference budget, task law, and success predicate must all be reported. Finite samples estimate this quantity; they do not reveal the unobserved tail without assumptions.
Definition. Uniform task-family acquisition witness [ftip-005X]AGENTDRAFTED
Definition. Uniform task-family acquisition witness [ftip-005X]AGENTDRAFTED
Fix a finite, independently selected family \(G\subseteq \mathcal X_{\mathsf T_{\rm ev}}\), thresholds \(0\leq \alpha <\beta \leq 1\), and the common evaluation interface of Convention [ftip-005D]. Protocols \(P_0\) and \(P_1\) have a uniform task-family acquisition witness on \(G\) when
\[ p_{P_0}(x)\leq \alpha \quad \hbox {and}\quad p_{P_1}(x)\geq \beta \qquad \text {for every }x\in G. \]For each \(x\), the successful event in Definition [ftip-005U] supplies the fixed-budget transfer event in Definition [ftip-0007]. The displayed inequalities specialize that earlier acquisition witness with \(\varepsilon _0=\alpha \) and \(\varepsilon _1=\beta \), then require the specialization uniformly over \(G\).
Remark. Acquisition evidence across a fixed task family [ftip-005Y]AGENTDRAFTED
Remark. Acquisition evidence across a fixed task family [ftip-005Y]AGENTDRAFTED
The proposed family-level criterion is a demanding paired comparison. The task family and evaluator are fixed independently, and both protocols use the same inference budget. It is stronger than one acquisition witness because the threshold change must hold for every member of \(G\).
A theorem may strengthen the witness with confidence bounds, transfer to a predeclared related family, or a lower bound on newly successful support. Each strengthening requires additional sampling or structural assumptions.
Definition. Verifier error rates [ftip-005Z]AGENTDRAFTED
Definition. Verifier error rates [ftip-005Z]AGENTDRAFTED
Let \(S\in \{0,1\}\) be an independently defined success label and \(A\in \{0,1\}\) the verifier's accept decision on the same outcome. The false-accept and false-reject rates are
\[ \eta _+=\Pr (A=1\mid S=0), \qquad \eta _-=\Pr (A=0\mid S=1). \]Both rates are conditional on the task and outcome distribution used for the audit. They are undefined when the conditioning event has probability zero.
Remark. Verifier error under an independent audit law [ftip-0061]AGENTDRAFTED
Remark. Verifier error under an independent audit law [ftip-0061]AGENTDRAFTED
Verifier error is measured against an independent success label because a training reward cannot audit itself. The verifier and evidence interfaces are in Definition [ftip-0046]--Definition [ftip-0049]. DeepSeek-Prover-V2 [ren2025deepseekproverv2, Section 2.3, ``Reinforcement Learning''] supplies a proof-checking instance. The false-accept/false-reject decomposition is a binary measurement model.
The rates may vary by task, policy, trajectory length, and adversarial pressure. A low average error rate need not prevent reward hacking on the subpopulation favored by optimization.
Example. Reward hacking under an incomplete checker [ftip-0060]AGENTDRAFTED
Example. Reward hacking under an incomplete checker [ftip-0060]AGENTDRAFTED
Shifting probability mass toward a checker exploit raises proxy reward while reducing independently judged utility.
Let the three outputs be \(y_0=\text {41}\), \(y_1=\text {42}\), and \(y_2=\text {ignore; 42; done}\). The proxy accepts \(y_1,y_2\); the independent evaluator accepts only \(y_1\). Moving their probabilities from \((0.5,0.4,0.1)\) to \((0.1,0.1,0.8)\) changes expected proxy reward from \(0.5\) to \(0.9\), but true utility from \(0.4\) to \(0.1\).
Reward exploitation in formal verification is discussed in [ren2025deepseekproverv2, Section 3.2]. The constructed checker exposes one failure mechanism. It provides no basis for treating every executable verifier as incomplete or every proxy improvement as reward hacking.
Definition. Global policy entropy [ftip-0062]AGENTDRAFTED
Definition. Global policy entropy [ftip-0062]AGENTDRAFTED
Fix a finite action space, a finite horizon \(T\), and a declared distribution \(\mu _t\) over public histories at each position. The global policy entropy is the weighted average
\[ H_{\rm global}(\pi ) =\frac 1T\sum _{t=0}^{T-1} \mathbb E_{\mathsf H_t\sim \mu _t} \left [-\sum _a\pi (a\mid \mathsf H_t) \log \pi (a\mid \mathsf H_t)\right ]. \]The history distribution and action alphabet are part of the statistic.
We use the convention \(0\log 0=0\) in this and the following position-entropy formula.
Definition. Token-position entropy [ftip-0063]AGENTDRAFTED
Definition. Token-position entropy [ftip-0063]AGENTDRAFTED
Let \(T_{\rm tok}\) be the random number of generated tokens. For a one-based token position \(t\) satisfying \(\Pr (T_{\rm tok}\geq t)>0\), condition on \(T_{\rm tok}\geq t\) and let \(\xi _t\) be the token. The token-position entropy is
\[ H_t^{\rm pos} =-\sum _{v\in \mathcal V} \Pr (\xi _t=v\mid T_{\rm tok}\geq t) \log \Pr (\xi _t=v\mid T_{\rm tok}\geq t). \]This is the entropy of a position marginal. It is generally different from the history-conditioned entropy averaged in Definition [ftip-0062].
Definition. selected-token surprisal [shannon1948mathematical, Part I, Section 6] [ftip-0064]AGENTDRAFTED
Definition. selected-token surprisal [shannon1948mathematical, Part I, Section 6] [ftip-0064]AGENTDRAFTED
For a sampled token \(\xi _t\) under next-token law \(\pi (\,\cdot \mid \mathsf H_t)\), its surprisal is
\[-\log \pi (\xi _t\mid \mathsf H_t).\]It is a random value attached to the selected token. Its conditional expectation over the token equals the finite Shannon entropy of the next-token law.
Remark. Why the entropy statistics are not interchangeable [ftip-0065]AGENTDRAFTED
Remark. Why the entropy statistics are not interchangeable [ftip-0065]AGENTDRAFTED
Shannon's finite entropy A mathematical theory of communication[shannon1948mathematical] can be aggregated over different random objects. Global and position-level entropy statistics use different laws. Selected-token surprisal is a sample statistic, while the other two are expectations under declared history or position laws.
A training intervention can raise one quantity while lowering another. Later claims about exploration or collapse must name the statistic, sampling law, horizon, and conditioning event.
Definition. empirical squared-ratio excess [miao2026when, Theorem 2] [ftip-0066]AGENTDRAFTED
Definition. empirical squared-ratio excess [miao2026when, Theorem 2] [ftip-0066]AGENTDRAFTED
For token-level current-to-behavior ratios \(r_1,\ldots ,r_T\), DGG defines
\[\widehat \chi ^2=\frac 1T\sum _{i=1}^T(r_i^2-1).\]The source relates this statistic to an upper bound on language-model-head gradient energy through a batch-dependent constant. In a finite batch \(\widehat \chi ^2\) can be negative, so it is not automatically a nonnegative empirical Pearson divergence. The result also gives no converse from a small batch gradient to small policy shift.
Example. Lifecycle compute allocation and a finite rollout observation bound [ftip-0067]AGENTDRAFTED
Example. Lifecycle compute allocation and a finite rollout observation bound [ftip-0067]AGENTDRAFTED
A componentwise lifecycle allocation separates resource accounting from the finite number of rollouts available for observation.
In the coordinate order of Definition [ftip-005H], declare a lifecycle budget vector \(\mathbf B\). Its rollout coordinate permits \(N\) attempts. If each attempt has declared success probability \(p\), then \[ \Pr (\text {at least one success})=1-(1-p)^N\leq Np. \] Only the rollout coordinate enters this calculation; no sum or conversion among heterogeneous coordinates is defined.
The finite bound is the union bound applied to Bernoulli rollouts; finite-horizon success probabilities are standard policy-evaluation objects in [sutton2018reinforcement, Section 3.5]. Independence is needed only for the displayed exact expression. The budget vector is illustrative: neither empirical optimality nor interchangeability of heterogeneous units is inferred from it.
Remark. Finite questions and necessary assumptions [ftip-0068]AGENTDRAFTED
Remark. Finite questions and necessary assumptions [ftip-0068]AGENTDRAFTED
Finite analysis raises three questions: how conditional success rates bound long-horizon success, how replay-ratio concentration controls update error, and how trajectory extrapolation with periodic recovery affects evaluation regret. A cost comparison also depends on rollout, update, environment, storage, and evaluation work.
Finite counterexamples show why these questions need additional assumptions. Finite policies can separate the entropy statistics above. Two verifiers can agree on all observed training records yet differ on an unobserved adversarial region. Two parameter paths can share early low-rank summaries and diverge after a new successful rollout. These examples mark where additional assumptions are unavoidable.
The DGG and NExt papers motivate reuse and trajectory-compression hypotheses but do not establish these general results. Bounds on update error and extrapolation regret require assumptions relating the monitored quantities to the corresponding outcomes.
Finite consequences and obstructions [ftip-0075]AGENTDRAFTED
Finite consequences and obstructions [ftip-0075]AGENTDRAFTED
This section turns parts of the preceding setup into finite mathematical statements. The results concern declared probability spaces, finite decision sets, recorded feedback, or explicitly stated matrix models. They do not by themselves establish a scaling law for language-model capability.
We begin with discovery and support, then study proxy rewards and verifiers. The third subsection asks what can be learned from a fixed feedback transcript. The last subsection studies the DGG inequalities before introducing trajectory-compression diagnostics and counterexamples.
Finite discovery and support [ftip-0076]AGENTDRAFTED
Finite discovery and support [ftip-0076]AGENTDRAFTED
A successful continuation can have positive probability and still be difficult to observe within a finite rollout budget. This subsection separates the probability of observing a success from support, coverage, and capability acquisition.
Convention. Repeated attempts and the discovery event [ftip-0077]AGENTDRAFTED
Convention. Repeated attempts and the discovery event [ftip-0077]AGENTDRAFTED
Fix a task instance, evaluator, success threshold, and a joint law for \(B\geq 1\) attempts. Let \(E_i\) be the event that attempt \(i\) succeeds. The discovery event by attempt \(B\) is
\[ D_B=\bigcup _{i=1}^{B}E_i. \]Write \(p_i=\Pr (E_i)\). Independence is an additional property of the declared joint law; it is not implied by repeated decoding, a shared model, or a common environment. In the independent and identically distributed case, write \(p_i=p\). When the attempt law is the one fixed in Definition [ftip-005U], this \(p\) is the corresponding successful-support probability.
Theorem. Discovery under independent attempts [ftip-0078]AGENTDRAFTED
Theorem. Discovery under independent attempts [ftip-0078]AGENTDRAFTED
Assume the events \(E_1,\ldots ,E_B\) of Convention [ftip-0077] are independent. Then
\[ \Pr (D_B)=1-\prod _{i=1}^{B}(1-p_i). \]In particular, independent attempts with a common success probability \(p\) satisfy
\[ \Pr (D_B)=1-(1-p)^B. \]
Proof.
Proof.
The complement of discovery is \(D_B^{\mathsf c}=\bigcap _{i=1}^{B}E_i^{\mathsf c}\). Independence gives \(\Pr (D_B^{\mathsf c})=\prod _i\Pr (E_i^{\mathsf c}) =\prod _i(1-p_i)\). Taking complements proves the first identity; substituting \(p_i=p\) proves the specialization.
This finite statement follows from the displayed hypotheses. The calculation in Example [ftip-0067] is its ten-attempt numerical preview.
Corollary. A rollout budget for target discovery probability [ftip-0079]AGENTDRAFTED
Corollary. A rollout budget for target discovery probability [ftip-0079]AGENTDRAFTED
This is a finite corollary of Theorem [ftip-0078], obtained from its displayed hypotheses.
Let \(0<\delta <1\). Under the independent and identically distributed setup of Theorem [ftip-0078], suppose first that \(0<p<1\). The least positive integer budget whose discovery failure probability is at most \(\delta \) is
\[ B_{\min } =\left \lceil \frac {\log \delta }{\log (1-p)}\right \rceil . \]If \(p=0\), no finite positive budget reaches failure probability below one. If \(p=1\), one attempt suffices.
Proof.
Proof.
For \(0<p<1\), Theorem [ftip-0078] gives failure probability \((1-p)^B\). The inequality \((1-p)^B\leq \delta \) is equivalent to \(B\geq \frac {\log \delta }{\log (1-p)}\) because both logarithms are negative. The least integer solution is the displayed ceiling. The two boundary cases follow directly from \((1-p)^B\).
Lemma. Discovery bounds from conditional success rates [ftip-007A]AGENTDRAFTED
Lemma. Discovery bounds from conditional success rates [ftip-007A]AGENTDRAFTED
Put \(D_0=\varnothing \). Whenever \(\Pr (D_{i-1}^{\mathsf c})>0\), define the surviving conditional success rate
\[ q_i=\Pr (E_i\mid D_{i-1}^{\mathsf c}). \]If these rates are defined through step \(B\), then
\[ \Pr (D_B^{\mathsf c})=\prod _{i=1}^{B}(1-q_i). \]Consequently, if \(0\leq \underline q\leq q_i\leq \overline q\leq 1\) for every surviving step, then
\[ 1-(1-\underline q)^B \leq \Pr (D_B) \leq 1-(1-\overline q)^B. \]
Proof.
Proof.
The chain rule gives \(\Pr (D_i^{\mathsf c})=\Pr (D_{i-1}^{\mathsf c})(1-q_i)\). Iteration proves the product identity, and the coordinatewise bounds on \(1-q_i\) give the two discovery bounds.
No independence assumption is used. The conditional rates may change with the earlier failures, an adaptive decoder, or a changing environment state.
This finite statement follows from the displayed hypotheses.
Remark. Discovery is neither acquisition nor coverage [ftip-007B]AGENTDRAFTED
Remark. Discovery is neither acquisition nor coverage [ftip-007B]AGENTDRAFTED
The discovery event concerns whether a declared sampling procedure observes at least one success. Increasing its probability can be an elicitation effect in the sense of Definition [ftip-0005]: more attempts expose behaviour that already had positive probability. It is not by itself the independent before--after comparison required by Definition [ftip-0007].
Successful-support coverage in Definition [ftip-005V] integrates an instance-level threshold over a task law. A large discovery probability on one instance therefore does not establish broad coverage or the uniform task-family witness of Definition [ftip-005X].
Theorem. Finite exponential tilting preserves support [ftip-007C]AGENTDRAFTED
Theorem. Finite exponential tilting preserves support [ftip-007C]AGENTDRAFTED
Fix a prompt \(x\), a finite response set \(\mathcal Y\), a reference policy \(\pi _{\mathrm {ref}}\), a finite real reward \(r(x,y)\), and \(\beta >0\). Let \(\pi _r\) be the normalized exponential tilt of Definition [ftip-003O]. Then, for every \(y\in \mathcal Y\),
\[ \pi _r(y\mid x)>0 \quad \Longleftrightarrow \quad \pi _{\mathrm {ref}}(y\mid x)>0. \]
Proof.
Proof.
The multiplier \(\exp (r(x,y)/\beta )\) is finite and strictly positive. The finite normalizer \(Z_r(x)\) is also strictly positive. Multiplication by the first quantity and division by the second therefore preserve whether the reference mass is zero or positive.
The source policy form appears as equation (4) in [rafailov2023direct, Section 4]; the displayed result is the finite corollary derived here. Infinite rewards, non-normalizable response spaces, approximate optimization, and changes to the generation mechanism lie outside the statement.
Remark. Formal support and operational discoverability [ftip-007D]AGENTDRAFTED
Remark. Formal support and operational discoverability [ftip-007D]AGENTDRAFTED
Support preservation is a statement about exact positive probability. A response can remain in mathematical support while its mass becomes too small to observe within the available rollout budget. The identities in Theorem [ftip-0078] and Corollary [ftip-0079] quantify this distinction for declared independent attempts.
Top-\(k\) truncation, nucleus sampling, finite numerical precision, context limits, and parser constraints can also remove an operational route even when the underlying softmax law assigns it positive mass. Claims about elicitation must therefore name both the policy law and the executable inference procedure.
Example. Counterexample: Equal one-shot success, unequal successful coverage [ftip-007E]AGENTDRAFTED
Example. Counterexample: Equal one-shot success, unequal successful coverage [ftip-007E]AGENTDRAFTED
Let the evaluation law be uniform on two instances \(x_1,x_2\). Consider protocols \(P\) and \(P'\) with successful-support probabilities
\[ \bigl (p_P(x_1),p_P(x_2)\bigr ) =\left (\frac 12,\frac 12\right ), \qquad \bigl (p_{P'}(x_1),p_{P'}(x_2)\bigr ) =(1,0). \]Both protocols have mean one-shot success \(1/2\). At threshold \(\alpha =1/2\), however, Definition [ftip-005V] gives
\[ \operatorname {Cov}_{1/2}(P)=1, \qquad \operatorname {Cov}_{1/2}(P')=\frac 12. \]Thus average success does not determine successful-support coverage. The example is finite and uses the same task law and threshold for both protocols; it does not compare their training costs or establish acquisition.
Proxy reward and verifier fidelity [ftip-007F]AGENTDRAFTED
Proxy reward and verifier fidelity [ftip-007F]AGENTDRAFTED
A proxy can guide an update or rank sampled candidates without agreeing with the independently declared utility of the resulting output. This subsection separates pointwise proxy error from average error under a shifted law. It then distinguishes repeated false-accept events from the output of a candidate selector. Pointwise approximation and explicit probability assumptions support different guarantees; an average audit number alone supplies neither.
Definition. Uniform proxy approximation [ftip-007G]AGENTDRAFTED
Definition. Uniform proxy approximation [ftip-007G]AGENTDRAFTED
Let \(\mathcal Y_0\) be a nonempty finite set of candidate outcomes. Let \(U:\mathcal Y_0\to \mathbb R\) be an independently declared utility and \(\widehat U:\mathcal Y_0\to \mathbb R\) a proxy score. The proxy is a uniform approximation to \(U\) on \(\mathcal Y_0\) with error \(\varepsilon \) when \(\varepsilon \geq 0\) and
\[ \sup _{y\in \mathcal Y_0}\lvert \widehat U(y)-U(y)\rvert \leq \varepsilon . \]The candidate set is part of the claim. Approximation on training outcomes, on one policy's support, or in expectation is not uniform approximation on a larger set reached after optimization.
Theorem. Uniform proxy error gives two-epsilon selection regret [ftip-007H]AGENTDRAFTED
Theorem. Uniform proxy error gives two-epsilon selection regret [ftip-007H]AGENTDRAFTED
Under the conditions of Definition [ftip-007G], choose
\[ y^\star \in \operatorname *{arg\,max}_{y\in \mathcal Y_0}U(y), \qquad \widehat y\in \operatorname *{arg\,max}_{y\in \mathcal Y_0}\widehat U(y). \]Then the utility regret of selecting by the proxy satisfies
\[ 0\leq U(y^\star )-U(\widehat y)\leq 2\varepsilon . \]
Proof.
Proof.
Optimality of \(\widehat y\) for the proxy and the two pointwise error bounds give
\[ \begin {aligned} U(y^\star ) &\leq \widehat U(y^\star )+\varepsilon \\ &\leq \widehat U(\widehat y)+\varepsilon \\ &\leq U(\widehat y)+2\varepsilon . \end {aligned} \]Optimality of \(y^\star \) for \(U\) gives the lower bound.
This finite statement follows from the displayed hypotheses.
Remark. The two-epsilon theorem is a decision bound [ftip-007I]AGENTDRAFTED
Remark. The two-epsilon theorem is a decision bound [ftip-007I]AGENTDRAFTED
The bound in Theorem [ftip-007H] follows directly from the uniform approximation condition. It compares two maximizers on one fixed finite candidate set. It does not describe how either score was learned or how a policy changes when that score becomes a training objective.
The result is useful because its transfer assumption is visible. To apply it after an update or a larger search, the uniform bound must hold on the outcomes that the new procedure can actually select. The verifier evidence of Definition [ftip-0047] can support such an audit, but reproducible evidence alone does not establish the bound.
Example. Counterexample: Small average proxy error fails after distribution shift [ftip-007J]AGENTDRAFTED
Example. Counterexample: Small average proxy error fails after distribution shift [ftip-007J]AGENTDRAFTED
Let the finite decision set be \(\mathcal Y_0=\{y_{\rm safe},y_{\rm exploit}\}\). Define its utility and proxy utility by the following table.
\[ \begin {array}{c|cc} &y_{\rm safe}&y_{\rm exploit}\\ \hline U&1&0\\ \widehat U&1&2. \end {array} \]For \(0<\delta <1\), let a reference law \(P_\delta \) assign probability \(\delta \) to \(y_{\rm exploit}\). Its mean absolute proxy error is
\[ \mathbb E_{P_\delta }\lvert \widehat U-U\rvert =2\delta , \]which tends to zero with \(\delta \). Nevertheless, proxy maximization selects \(y_{\rm exploit}\) and incurs utility regret \(1\). Under the shifted law concentrated on that selected outcome, the mean error is \(2\). Thus no vanishing selection-regret bound can depend only on average error under the reference law.
This two-outcome construction isolates the distribution-shift warning in Remark [ftip-0061]. It does not claim that a particular learned verifier has this error profile; Example [ftip-0060] gives a source-linked checker instance with the same proxy-versus-utility separation.
Definition. Repeated verifier audit [ftip-007K]AGENTDRAFTED
Definition. Repeated verifier audit [ftip-007K]AGENTDRAFTED
A repeated verifier audit of size \(N\geq 1\) records pairs \((S_i,A_i)\in \{0,1\}^2\) for candidates \(1\leq i\leq N\). Here \(S_i\) is an independently defined success label and \(A_i\) is the verifier decision, as in Definition [ftip-005Z]. Define
\[ C_i^{\rm fa}=\{S_i=0,\ A_i=1\}, \qquad \mathcal E_N^{\rm fa}=\bigcup _{i=1}^N C_i^{\rm fa}. \]The event \(\mathcal E_N^{\rm fa}\) says that at least one invalid candidate was accepted. It does not say which candidate a downstream selector returns. Write \(\phi _i=\Pr (C_i^{\rm fa})\). When \(\iota _i=\Pr (S_i=0)>0\), the conditional false-accept rate \(\eta _{+,i}=\Pr (A_i=1\mid S_i=0)\) is defined and \(\phi _i=\iota _i\eta _{+,i}\).
Theorem. Independent false accepts amplify with candidate count [ftip-007L]AGENTDRAFTED
Theorem. Independent false accepts amplify with candidate count [ftip-007L]AGENTDRAFTED
In the repeated audit of Definition [ftip-007K], suppose the pairs \((S_i,A_i)\) are independent and identically distributed. Assume
\[ \iota =\Pr (S_i=0)>0, \qquad \eta _+=\Pr (A_i=1\mid S_i=0). \]Then the probability that at least one accepted invalid candidate exists among the \(N\) audited candidates is
\[ \Pr (\mathcal E_N^{\rm fa})=1-(1-\iota \eta _+)^N. \]It is strictly increasing in \(N\) when \(0<\iota \eta _+<1\), and it converges to \(1\) when \(\iota \eta _+>0\).
Proof.
Proof.
Each \(C_i^{\rm fa}\) has probability \(\iota \eta _+\). Independence of the audited pairs makes the events \(C_i^{\rm fa}\) independent. Therefore
\[ \Pr \left ((\mathcal E_N^{\rm fa})^c\right ) =\Pr \left (\bigcap _{i=1}^N (C_i^{\rm fa})^c\right ) =\prod _{i=1}^N(1-\iota \eta _+) =(1-\iota \eta _+)^N. \]Taking complements gives the equality. The monotonicity and limit follow from the elementary powers of \(1-\iota \eta _+\).
This finite statement follows from the displayed hypotheses.
Theorem. A false-accept union bound without independence [ftip-007M]AGENTDRAFTED
Theorem. A false-accept union bound without independence [ftip-007M]AGENTDRAFTED
For any joint law of a repeated verifier audit,
\[ \Pr (\mathcal E_N^{\rm fa})\leq \sum _{i=1}^N \phi _i. \]If \(\iota _i=\Pr (S_i=0)>0\) for every \(i\), this becomes
\[ \Pr (\mathcal E_N^{\rm fa})\leq \sum _{i=1}^N \iota _i\eta _{+,i}. \]
Proof.
Proof.
Apply the union bound to \(\mathcal E_N^{\rm fa}=\bigcup _i C_i^{\rm fa}\). The factorization \(\phi _i=\iota _i\eta _{+,i}\) follows from conditional probability whenever \(\iota _i>0\). If \(\iota _i=0\), then \(\phi _i=0\) while the corresponding conditional rate is undefined, so the first display remains the unconditional statement.
Without a dependence assumption, matching marginal error rates do not give the equality in Theorem [ftip-007L]; the events \(C_i^{\rm fa}\) could coincide.
This finite statement follows from the displayed hypotheses.
Example. Weight updates and candidate selection are different proxy operators [ftip-007N]AGENTDRAFTED
Example. Weight updates and candidate selection are different proxy operators [ftip-007N]AGENTDRAFTED
A proxy score can enter a training operator or a selection operator. In the first route it changes the policy; in the second it ranks a finite sample from a policy whose weights remain fixed.
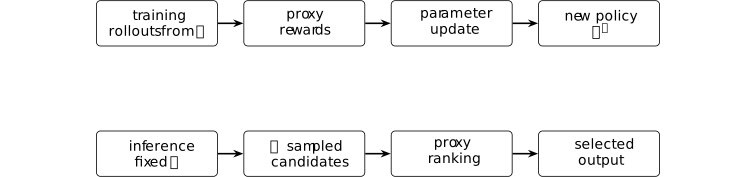
The lifecycle accounting of Definition [ftip-005H] places the first route's rollout and update work in separate coordinates. The second route incurs rollout and evaluation work but no parameter update. Consequently, the event \(\mathcal E_N^{\rm fa}\) in Definition [ftip-007K] concerns the candidate set presented to selection; it is not a claim about the selected output or a training-time policy change.
Remark. What verifier error rates do not identify [ftip-007O]AGENTDRAFTED
Remark. What verifier error rates do not identify [ftip-007O]AGENTDRAFTED
The rates in Definition [ftip-005Z] are properties of a declared audit law. They do not identify where errors occur within the task family, how error events depend across repeated candidates, or which accepted candidate a selector returns. Theorem [ftip-007L] adds identical marginals and independence; Theorem [ftip-007M] retains only the union bound.
Nor do these rates determine the effect of optimizing against the verifier. That effect depends on how the induced policy or selection law moves mass toward particular outcomes. The incomplete-checker example Example [ftip-0060] demonstrates one such movement, while Example [ftip-007J] shows why an average reference-law error cannot rule it out. These are local finite statements. Any claim about a named verifier still requires its own audit distribution, evidence, and transfer argument.
The deterministic regret lemma Theorem [ftip-007H], the independent-audit identity Theorem [ftip-007L], and the union bound Theorem [ftip-007M] follow from uniform approximation, independent trials, and subadditivity, respectively. Their hypotheses need not hold for a verifier chosen only for its empirical performance.
Feedback identifiability and fixed records [ftip-007P]AGENTDRAFTED
Feedback identifiability and fixed records [ftip-007P]AGENTDRAFTED
A training protocol can respond only to distinctions present in its observations. The following finite setup makes that restriction precise before considering stronger, model-specific limits on preference data.
Definition. Finite declared feedback protocol [ftip-007Q]AGENTDRAFTED
Definition. Finite declared feedback protocol [ftip-007Q]AGENTDRAFTED
Fix a horizon \(N\geq 0\), finite action sets \(\mathcal A_n\), finite feedback sets \(\mathcal F_n\), and a finite internal-seed set \(\mathcal U\) with a declared law \(\lambda \). A finite declared protocol \(\mathsf P\) consists of selection maps
\[ a_n:\mathcal U\times \prod _{j<n}(\mathcal A_j\times \mathcal F_j) \longrightarrow \mathcal A_n \qquad (0\leq n<N). \]An action may specify the task, rollout record, feedback request, or sampling choice made at that round. The protocol can depend on earlier exposed feedback and its declared seed, but it cannot depend on a latent world field that has not entered those arguments.
Definition. Finite feedback world [ftip-008C]AGENTDRAFTED
Definition. Finite feedback world [ftip-008C]AGENTDRAFTED
For the action and feedback sets of Definition [ftip-007Q], a finite feedback world \(w\) supplies, for each round \(0\leq n<N\), a probability kernel \(K_{n,w}\) from a generic action--feedback history \((a_0,f_0,\ldots ,a_n)\) ending in \(a_n\in \mathcal A_n\) to \(\mathcal F_n\). Thus, whenever \(a_j\in \mathcal A_j\) and \(f_j\in \mathcal F_j\),
\[ K_{n,w}(\,\cdot \mid a_0,f_0,\ldots ,a_n) \in \Delta (\mathcal F_n). \]Two worlds may agree on every feedback kernel queried by a protocol while differing in latent utility, unrequested labels, or unobserved environment facts. Those latent fields are not feedback until a declared query exposes them.
Definition. Observed feedback transcript [ftip-008D]AGENTDRAFTED
Definition. Observed feedback transcript [ftip-008D]AGENTDRAFTED
Fix a finite declared protocol \(\mathsf P\) from Definition [ftip-007Q] and a finite feedback world \(w\) from Definition [ftip-008C]. Draw \(U\sim \lambda \) and, for \(0\leq n<N\), set
\[ \begin {aligned} A_n&=a_n(U,A_0,F_0,\ldots ,A_{n-1},F_{n-1}),\\ F_n&\sim K_{n,w}(\,\cdot \mid A_0,F_0,\ldots ,A_n). \end {aligned} \]The resulting observed feedback transcript is
\[ T_w^{\mathsf P}=(U,A_0,F_0,\ldots ,A_{N-1},F_{N-1}). \]All protocol randomness is included in \(U\). Immutable rollout records and typed feedback events may be components of the finite action and feedback sets, as in Definition [ftip-0051] and Definition [ftip-0053].
Definition. Observational equivalence for a declared protocol [ftip-007R]AGENTDRAFTED
Definition. Observational equivalence for a declared protocol [ftip-007R]AGENTDRAFTED
Let \(\mathcal T_{\mathsf P}\) be the finite set of possible transcripts for a declared protocol \(\mathsf P\). Two feedback worlds \(w_0,w_1\) are observationally equivalent for \(\mathsf P\), written \(w_0\equiv _{\mathsf P}w_1\), when
\[ \Pr (T_{w_0}^{\mathsf P}=t)=\Pr (T_{w_1}^{\mathsf P}=t) \qquad \text {for every }t\in \mathcal T_{\mathsf P}. \]The relation is protocol-relative. Another protocol may issue a different feedback request and thereby separate the same worlds. Equality only on the realized transcript is weaker than this definition, which compares the whole finite transcript law.
Theorem. Post-training cannot distinguish observationally equivalent worlds [ftip-007S]AGENTDRAFTED
Theorem. Post-training cannot distinguish observationally equivalent worlds [ftip-007S]AGENTDRAFTED
For a finite random variable \(X\), write \(\operatorname {Law}(X)\) for its probability law. If \(h\) maps the value space of \(X\) to a finite set \(\mathcal Y\), its pushforward law \(h_{\#}\operatorname {Law}(X)\) is characterized by \[ \bigl (h_{\#}\operatorname {Law}(X)\bigr )(\{y\}) =\Pr (h(X)=y),\qquad y\in \mathcal Y. \]
Let \(w_0\equiv _{\mathsf P}w_1\). For any finite output set \(\mathcal Y\) and any readout \(h:\mathcal T_{\mathsf P}\to \mathcal Y\),
\[ h_{\#}\operatorname {Law}(T_{w_0}^{\mathsf P}) =h_{\#}\operatorname {Law}(T_{w_1}^{\mathsf P}). \]Thus a final artifact stamp, update decision, or test chosen solely from the declared protocol's transcript has the same distribution in both worlds.
Proof.
Proof.
For every \(y\in \mathcal Y\), finiteness gives
\[ \begin {aligned} \Pr \left (h(T_{w_0}^{\mathsf P})=y\right ) &=\sum _{\substack {t\in \mathcal T_{\mathsf P}\\h(t)=y}} \Pr (T_{w_0}^{\mathsf P}=t)\\ &=\sum _{\substack {t\in \mathcal T_{\mathsf P}\\h(t)=y}} \Pr (T_{w_1}^{\mathsf P}=t) =\Pr \left (h(T_{w_1}^{\mathsf P})=y\right ). \end {aligned} \]The middle equality is observational equivalence from Definition [ftip-007R]. These point probabilities determine the two pushforward laws.
This finite statement follows from the displayed hypotheses.
Remark. A no-free-feedback result, not a no-learning result [ftip-007T]AGENTDRAFTED
Remark. A no-free-feedback result, not a no-learning result [ftip-007T]AGENTDRAFTED
Theorem [ftip-007S] says that the declared observations supply no information that distinguishes \(w_0\) from \(w_1\). It does not say that the output must equal the initial model, that the parameters cannot change, or that performance cannot improve in both worlds. Pretraining, inductive bias, computation on the observed records, and generalization may still produce an improvement shared by the two worlds.
Calling the theorem a no-learning result would therefore erase the central condition: only world-dependent conclusions unavailable from the common transcript are ruled out.
Corollary. Replaying a fixed pool supplies no new feedback information [ftip-007U]AGENTDRAFTED
Corollary. Replaying a fixed pool supplies no new feedback information [ftip-007U]AGENTDRAFTED
Fix a realized finite replay pool \(d\) as in Definition [ftip-0056]. Let \(\mathcal V\) be a finite seed set, and let \(V\in \mathcal V\) be a replay-and-update seed with the same declared law in two feedback worlds and whose law does not depend on the world. If a replay-only procedure makes no new environment or feedback query, then its output has the form \(Y=h(d,V)\). The law of \(Y\) is the same in the two worlds.
Proof.
Proof.
For every output \(y\),
\[ \Pr (h(d,V)=y)= \sum _{\substack {v\in \mathcal V\\h(d,v)=y}}\Pr (V=v). \]The fixed pool, seed law, and readout are identical in the two worlds, so the displayed sum is identical. Equivalently, this is the pushforward argument of Theorem [ftip-007S] applied after conditioning on the realized pool.
This finite statement follows from the displayed hypotheses.
Remark. Reuse can change optimization without enlarging evidence [ftip-007V]AGENTDRAFTED
Remark. Reuse can change optimization without enlarging evidence [ftip-007V]AGENTDRAFTED
A replay schedule can reweight records, reduce optimization error on the fixed pool, or produce a different update proposal in the sense of Definition [ftip-006C]. Those are genuine computational effects. They do not add a label, preference, verifier result, or environment transition to the fixed evidence. Fresh optimizer randomness is likewise not feedback about the latent world.
This distinction prevents sample reuse from being counted as feedback acquisition. It does not imply that replay is useless; it isolates the source of any benefit as further computation on already acquired records.
Example. Counterexample: An off-query utility reversal [ftip-007W]AGENTDRAFTED
Example. Counterexample: An off-query utility reversal [ftip-007W]AGENTDRAFTED
Let the response set be \(\{a,b\}\). A one-round protocol queries only \(x_0\); both worlds return the preference \(a\succ b\). The protocol therefore has the same transcript law in both worlds. Fix a deterministic transcript-to-policy readout that chooses \(a\) also at an unqueried \(x_1\). The worlds agree on every observed field but reverse utility at \(x_1\):
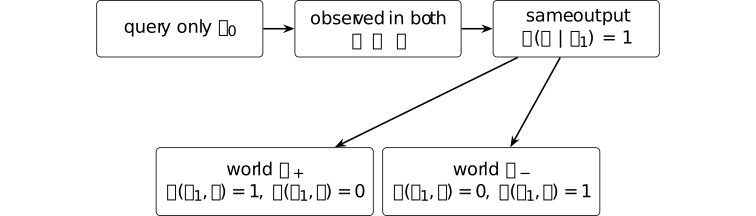
The transcript laws are identical, so Theorem [ftip-007S] applies, while the deterministic readout returns the same output in both worlds. That output is optimal in \(w_+\) and suboptimal in \(w_-\) on \(x_1\). The example does not show that generalization always fails. It shows that a claim about unqueried utility requires an assumption connecting observed feedback to that utility.
Remark. From finite indistinguishability to preference-data limits [ftip-007X]AGENTDRAFTED
Remark. From finite indistinguishability to preference-data limits [ftip-007X]AGENTDRAFTED
[zhao2025limits, Theorems 3.3--3.5] study a more structured post-training model. They give ordinal-preference distortion lower bounds, including a lower bound under Bradley--Terry noise with linear scores, and a positive result using a limited number of cardinal queries. These results depend on the routing model, utility class, and query budget developed in § [ftip-008X].
Theorem [ftip-007S] gives a finite pushforward theorem, while Example [ftip-007W] gives a counterexample to identification from an incomplete transcript. They are neither proofs nor special cases of the paper's distortion results.
Replay monitors and trajectory compression [ftip-007Y]AGENTDRAFTED
Replay monitors and trajectory compression [ftip-007Y]AGENTDRAFTED
Reusing a rollout and jumping along a predicted checkpoint path save different kinds of work. The first changes how often recorded feedback enters an update. The second replaces some realized training steps by a parameter forecast. This subsection records what their proposed monitors establish and, separately, what remains unmeasured.
Theorem. DGG head gradient and shared-weight occurrence sum [ftip-007Z]AGENTDRAFTED
Theorem. DGG head gradient and shared-weight occurrence sum [ftip-007Z]AGENTDRAFTED
Fix a sampled history and an active token \(i\) in the interior of the unclipped branch of the GRPO objective. Consider a finite directed acyclic computation graph that is differentiable at the parameter point in question. Let \(a_i\) be the sampled token, \(\widehat A_i\) its fixed normalized advantage, and \(p_i=\operatorname {softmax}(z_i)\) the current distribution on a finite vocabulary \(\mathcal V\). With fixed behavior probability \(b_i>0\), set \[ r_i=\frac {p_i(a_i)}{b_i}, \qquad \mathcal L_i=r_i\widehat A_i, \qquad E_i=r_i\widehat A_i(e_{a_i}-p_i). \] Here \(e_{a_i}\in \mathbb R^{|\mathcal V|}\) is the sampled-token basis vector. The history and sampling decisions are held fixed during differentiation.
Suppose the output head \(W_{\rm lm}\in \mathbb R^{|\mathcal V|\times d_{\rm model}}\) is untied: its only path to \(\mathcal L_i\) is through \(z_i=W_{\rm lm}h_{L,i}\), and \(h_{L,i}\in \mathbb R^{d_{\rm model}}\) is independent of \(W_{\rm lm}\). Then \[ G_i^{\rm lm}=\nabla _{W_{\rm lm}}\mathcal L_i =E_i h_{L,i}^{\mathsf T}. \]
Let \(W_{\rm int}\in \mathbb R^{m\times d}\) be a shared intermediate weight. Index by a finite set \(\mathcal O_i\) every occurrence of this weight that can affect \(z_i\), assuming that all such uses have the form \(y_o=W_{\rm int}x_o\), with \(x_o\in \mathbb R^d\). First replace these uses by independent copies \(W_o\) and evaluate them all at \(W_o=W_{\rm int}\). Let \(J_{io}\in \mathbb R^{|\mathcal V|\times m}\) be the downstream Jacobian from node \(y_o\) to \(z_i\) in this graph, with the other weight copies fixed. Define the contribution of occurrence \(o\) by \[ H_{io}=\nabla _{W_o}\mathcal L_i =(J_{io}^{\mathsf T}E_i)x_o^{\mathsf T}. \] On tying the copies, the total derivative is \[ G_i^{\rm int}=\nabla _{W_{\rm int}}\mathcal L_i =\sum _{o\in \mathcal O_i}H_{io}. \] The head gradient and each occurrence contribution have rank at most one; the total shared-weight gradient need not.
For a layer used once per position in a causal network, the sum includes every earlier position whose output affects token \(i\). Reuse across depth adds further occurrences. Tying the head to embeddings or other blocks also requires their contributions; the displayed head identity assumes that such tying is absent.
Proof.
Proof.
Softmax differentiation gives \(\nabla _{z_i}\mathcal L_i=E_i\). The outer-product rule gives the untied head identity. In the graph with independent copies, \(x_o\) does not depend on its own \(W_o\); all downstream paths from \(y_o\) are included in \(J_{io}\). The chain rule therefore gives \(\nabla _{W_o}\mathcal L_i=(J_{io}^{\mathsf T}E_i)x_o^{\mathsf T}\). Finally, the derivative of the diagonal map \(W_{\rm int}\mapsto (W_o=W_{\rm int})_{o\in \mathcal O_i}\) adds these partial derivatives.
Clipped or inactive terms require their own derivative or mask. [miao2026when, Section 4.2.1, Proposition 1, and Appendix A.1] derives the intermediate outer product through one local application. For a shared weight, that calculation gives \(H_{io}\); identifying it with the total \(G_i^{\rm int}\) omits the other occurrences. The sum above supplies the chain rule needed for shared parameters.
Theorem. DGG occurrence-to-head gradient-energy bound [ftip-0080]AGENTDRAFTED
Theorem. DGG occurrence-to-head gradient-energy bound [ftip-0080]AGENTDRAFTED
Use the per-token quantities and untied head of Theorem [ftip-007Z], and fix one occurrence \(o\in \mathcal O_i\). Assume \(d_{\rm model}\geq 1\) and positive constants \(\alpha _{\min }\), \(\beta _{\max }\), and \(C\) satisfy \[ \|h_{L,i}\|_2^2\geq \alpha _{\min }d_{\rm model}, \qquad \|x_o\|_2^2\leq \beta _{\max }d_{\rm model}, \] and the two logit-sensitivity bounds \[ \mathbb E_{a\sim p_i} \|(J_{io})_{a,:}\|_2^2\leq C, \qquad \|(J_{io})_{a_i,:}\|_2^2\leq C. \] If \(\widehat A_i\neq 0\) and \(p_i(a_i)<1\), then \[ \frac {\|H_{io}\|_F^2}{\|G_i^{\rm lm}\|_F^2} \leq \frac {\mathcal C_{\rm occ}} {(1-p_i(a_i))^2}, \qquad \mathcal C_{\rm occ} =\frac {4\beta _{\max }C}{\alpha _{\min }}. \]
Proof.
Proof.
The sampled-token coordinate of \(E_i\) and the lower activation bound give \[ \|G_i^{\rm lm}\|_F^2 =\|E_i\|_2^2\|h_{L,i}\|_2^2 \geq r_i^2\widehat A_i^2 (1-p_i(a_i))^2 \alpha _{\min }d_{\rm model}. \] Write \(J_{io}^{\mathsf T}E_i\) as \(r_i\widehat A_i\) times the difference between the sampled row and the \(p_i\)-weighted mean row. The squared-norm inequality \(\|u-v\|_2^2\leq 2\|u\|_2^2+2\|v\|_2^2\), Jensen's inequality for that mean, and the two row-energy bounds give \(\|J_{io}^{\mathsf T}E_i\|_2^2\leq 4r_i^2\widehat A_i^2C\). Hence \[ \|H_{io}\|_F^2 \leq 4r_i^2\widehat A_i^2C\, \beta _{\max }d_{\rm model}. \] The source's softmax probabilities make \(r_i>0\); the nonzero-advantage and nonunit-probability hypotheses make the head lower bound positive. Division and cancellation give the displayed ratio.
This bounds one occurrence contribution, not the total derivative of a shared intermediate weight. For the latter, the sum in Theorem [ftip-007Z] gives only \[ \|G_i^{\rm int}\|_F \leq \sum _{o\in \mathcal O_i} \|J_{io}^{\mathsf T}E_i\|_2\|x_o\|_2. \] If the same displayed hypotheses hold for every occurrence, the triangle inequality yields the ratio bound \(|\mathcal O_i|^2\mathcal C_{\rm occ}/(1-p_i(a_i))^2\) for \(\|G_i^{\rm int}\|_F^2/\|G_i^{\rm lm}\|_F^2\). Controlling only the application at position \(i\) does not establish this all-occurrence hypothesis or the source's claimed bound for the total gradient. The contributing positions, reuse pattern, and Jacobians depend on the architecture. Neither bound establishes a small gradient or an evaluation-score comparison.
The activation and row-energy hypotheses and the local inequality follow the calculation in [miao2026when, Section 4.2.1, Lemma 1, Assumption 1, Theorem 1, and Appendix A.3], with the differentiated object restricted to an occurrence contribution. They do not prove the source's total shared-weight claim under its local hypotheses.
Theorem. DGG finite-batch head-gradient inequality [ftip-0081]AGENTDRAFTED
Theorem. DGG finite-batch head-gradient inequality [ftip-0081]AGENTDRAFTED
For \(T\geq 1\) active, unclipped tokens with fixed sampled histories and the untied output head of Theorem [ftip-007Z], let \[ G^{\rm lm}=\frac 1T\sum _{i=1}^T G_i^{\rm lm}, \qquad \overline {r^2}=\frac 1T\sum _{i=1}^T r_i^2, \] and set \[ c_{\max }= \max _{1\leq i\leq T} \widehat A_i^2 \|e_{a_i}-\pi _\theta (\mathord \cdot \mid h_{L,i})\|_2^2 \|h_{L,i}\|_2^2. \] Then \[ \|G^{\rm lm}\|_F^2\leq c_{\max }\overline {r^2} =c_{\max }(1+\widehat \chi ^2), \] where \(\widehat \chi ^2\) is the statistic of Definition [ftip-0066]. If \(c_{\max }>0\), rearrangement gives the source's equivalent direction \[ \widehat \chi ^2\geq \frac {\|G^{\rm lm}\|_F^2}{c_{\max }}-1. \]
Proof.
Proof.
Convexity of the squared Frobenius norm and the factorization in Theorem [ftip-007Z] give \[ \left \|\frac 1T\sum _iG_i^{\rm lm}\right \|_F^2 \leq \frac 1T\sum _i\|G_i^{\rm lm}\|_F^2 \leq \frac {c_{\max }}T\sum _i r_i^2. \] The identity \(\overline {r^2}=1+\widehat \chi ^2\) follows directly from Definition [ftip-0066]; division by positive \(c_{\max }\) gives the final form.
The inequality points from observed head-gradient energy to a lower bound on this finite-batch squared-ratio statistic. It is not a converse: cancellation can hide nonunit ratios. The active cancellation example in Example [ftip-0084] states its clipping interval explicitly. The proof uses no intermediate-weight bound.
The finite-batch inequality follows the calculation in [miao2026when, Section 4.2.2, Lemma 2, Theorem 2, and Appendix B], under the untied-head and fixed-history assumptions stated above.
Remark. DGG monitors update geometry, not evaluation safety [ftip-0082]AGENTDRAFTED
Remark. DGG monitors update geometry, not evaluation safety [ftip-0082]AGENTDRAFTED
The identities in Theorem [ftip-007Z]--Theorem [ftip-0081] concern gradients, importance ratios, activations, and occurrence-specific logit Jacobians. The intermediate bound controls a local contribution; a shared-weight bound needs control over all contributing occurrences. None of their hypotheses mentions the fixed independent-evaluation functional \(J_{\rm ev}\) of Definition [ftip-005E]. They therefore cannot imply that accepting an update preserves \(J_{\rm ev}\), or that rejecting one would have prevented a decrease.
DGG adds an empirical policy on top of those identities: it monitors the increment in head-gradient energy, standardizes that increment against a trailing window, and rejects some reused updates before the optimizer step [miao2026when, Section 5 and Algorithm 1]. Its reported experiments relate that policy to observed training stability. They do not turn the Z-score into a calibrated test of independent-evaluation safety.
Example. Counterexample: empirical squared-ratio excess can be negative [ftip-0083]AGENTDRAFTED
Example. Counterexample: empirical squared-ratio excess can be negative [ftip-0083]AGENTDRAFTED
Take one observed action \(a\) with \(\pi _{\rm old}(a)=1/2\) and \(\pi _\theta (a)=1/4\). The batch contains only that action, so \(T=1\) and \(r_1=1/2\). Hence \[ \widehat \chi ^2=r_1^2-1=-\frac 34. \] Both policies can be completed on a two-action space by assigning their remaining mass to the other action.
Thus the finite-batch statistic in Definition [ftip-0066] need not share the nonnegativity of the population Pearson divergence. Theorem Theorem [ftip-0081] remains valid: its right side contains \(1+\widehat \chi ^2=1/4=\overline {r^2}\).
Example. Counterexample: active batch cancellation can hide nonunit ratios [ftip-0084]AGENTDRAFTED
Example. Counterexample: active batch cancellation can hide nonunit ratios [ftip-0084]AGENTDRAFTED
Fix \(\epsilon _{\rm clip}\in (0,1)\) and \(1<R<1+\epsilon _{\rm clip}\). On a two-token vocabulary, let both observed tokens have \(a_i=1\), current probability \(\pi _\theta (1)=1/2\), and behavior probability \(\pi _{\rm old}(1)=1/(2R)\). Take scalar hidden states \(h_{L,1}=h_{L,2}=1\) and fixed normalized advantages \(\widehat A_1=1\), \(\widehat A_2=-1\). These may be selected token terms from different rollout members. An untied head with both logits zero realizes the current probabilities. Both terms lie strictly inside the clipping interval of Definition [ftip-003F], so the clipped surrogate locally agrees with \(\mathcal L_i=r_i\widehat A_i\). Thus \(r_1=r_2=R\), and Theorem [ftip-007Z] gives \[ G_1^{\rm lm}=R(1/2,-1/2)^{\mathsf T}, \qquad G_2^{\rm lm}=-G_1^{\rm lm}. \] Consequently \(G^{\rm lm}=0\), while \(\widehat \chi ^2=R^2-1>0\). For this fixed clipping rule, the statistic in this construction is bounded above by \((1+\epsilon _{\rm clip})^2-1\).
For the raw surrogate \(\mathcal L_i=r_i\widehat A_i\) considered as a separate objective, the same algebra works at every \(R>1\) and yields arbitrarily large squared-ratio excess. This does not extend the active construction to arbitrary \(R\) under clipping: when \(R>1+\epsilon _{\rm clip}\), the positive-advantage term is locally constant, while the negative term remains active. Their clipped gradients are then \(0\) and \(-R(1/2,-1/2)^{\mathsf T}\), with nonzero mean \((-R/4,R/4)^{\mathsf T}\).
The example does not contradict Theorem [ftip-0081]: that theorem upper-bounds batch-gradient energy by a ratio moment. It supplies no lower bound on the gradient and no converse from zero batch-gradient energy to ratios equal to one. The arbitrary-ratio version concerns only the separate raw surrogate.
Example. Counterexample: a Z-score gate is not an evaluation-safety certificate [ftip-0085]AGENTDRAFTED
Example. Counterexample: a Z-score gate is not an evaluation-safety certificate [ftip-0085]AGENTDRAFTED
Let two consecutive proposed reused updates have the same monitored energy, \(g_{t-1}=g_t=1\). With trailing-window increment mean \(\mu _t=0\), any positive scale \(\sigma _t+\varepsilon \), and any positive threshold, DGG's score is \[ z_t=\frac {(g_t-g_{t-1})-\mu _t}{\sigma _t+\varepsilon }=0, \] so the gate accepts the proposal. Now choose a fixed evaluation interface for which the artifact before the accepted update has performance \(J_{\rm ev}=1\) and the artifact after it has performance \(J_{\rm ev}=0\).
This is consistent because the gate rule of Definition [ftip-005A] imposes no mathematical relation between its scalar monitor and \(J_{\rm ev}\). A safety claim would need an additional assumption connecting proposed updates to the independent evaluation law; the Z-score calculation alone cannot provide it.
Definition. Leading squared singular-energy share [ftip-0086]AGENTDRAFTED
Definition. Leading squared singular-energy share [ftip-0086]AGENTDRAFTED
Let \(\Delta W\in \mathbb R^{m\times n}\) be nonzero, set \(q=\min (m,n)\), and order its singular values as \(\sigma _1\geq \cdots \geq \sigma _q\geq 0\). Its leading squared singular-energy share is \[ \rho _1(\Delta W) =\frac {\sigma _1(\Delta W)^2}{\sum _{j=1}^q\sigma _j(\Delta W)^2} =\frac {\sigma _1(\Delta W)^2}{\|\Delta W\|_F^2}. \] The nonzero hypothesis prevents an undefined \(0/0\); the value lies in \([1/q,1]\).
NExt instead reports \(E_1=\sigma _1/\sum _j\sigma _j\) in Section 3.2 Low-rank optimization trajectories modeling for LLM RLVR acceleration[chen2026lowrank]. That nuclear-share statistic and \(\rho _1\) answer different questions. The squared share measures contribution to squared Frobenius norm.
Definition. Leading spectral gap [ftip-0087]AGENTDRAFTED
Definition. Leading spectral gap [ftip-0087]AGENTDRAFTED
For \(\Delta W\in \mathbb R^{m\times n}\) with \(q=\min (m,n)\geq 2\), its leading spectral gap is \[ \operatorname {gap}_1(\Delta W) =\sigma _1(\Delta W)-\sigma _2(\Delta W). \] A positive gap makes the leading left and right one-dimensional singular subspaces unique, although each chosen singular vector still has an arbitrary sign. When the gap is zero, a single leading vector is not intrinsic.
The quantity is undefined when \(q=1\), since there is no second singular value. Projector comparisons require a positive gap at every compared checkpoint.
Definition. Leading-subspace projector drift [ftip-0088]AGENTDRAFTED
Definition. Leading-subspace projector drift [ftip-0088]AGENTDRAFTED
Let \(\Delta W_t\) and \(\Delta W_s\) be nonzero matrices of the same shape, each with positive leading spectral gap. If \(u_1(t)\) and \(u_1(s)\) are unit leading left singular vectors, define their leading-subspace projector drift by \[ d_{\rm proj}(t,s) =\|\Pi _t^{\rm svd}-\Pi _s^{\rm svd}\|_F, \qquad \Pi _t^{\rm svd}=u_1(t)u_1(t)^{\mathsf T}, \quad \Pi _s^{\rm svd}=u_1(s)u_1(s)^{\mathsf T}. \] The definition is independent of both singular-vector signs and takes values in \([0,\sqrt {2}]\).
This is an additional proposed trajectory diagnostic; NExt does not define it.
A large value of \(\rho _1\) from Definition [ftip-0086] says that one singular mode dominates a particular difference matrix. It does not say that the dominant subspace remains fixed across checkpoints; \(d_{\rm proj}\) measures that separate question.
Definition. Path-emulation regret [ftip-0089]AGENTDRAFTED
Definition. Path-emulation regret [ftip-0089]AGENTDRAFTED
Fix the evaluation interface of Convention [ftip-005D]. Let \(P_{t+s}^{\rm act}\) be the protocol that returns the artifact reached after \(s\geq 1\) additional realized training steps from checkpoint \(t\). Let \(\mathcal K_{\leq t}\) be the saved checkpoint history available through \(t\), and let \(\widehat P_{t+s}(\mathcal K_{\leq t})\) instead return the artifact forecast from that history. Their signed path-emulation regret and absolute path-emulation regret are \[ \begin {aligned} \operatorname {Reg}^{\rm path}_{\rm ev}(t,s) &=J_{\rm ev}(P_{t+s}^{\rm act}) -J_{\rm ev}(\widehat P_{t+s}(\mathcal K_{\leq t})),\\ \operatorname {AReg}^{\rm path}_{\rm ev}(t,s) &=\left |\operatorname {Reg}^{\rm path}_{\rm ev}(t,s)\right |. \end {aligned} \]
The sign distinguishes an optimistic forecast from a pessimistic one; the absolute value measures discrepancy without cancellation across checkpoints. Both use the same task law, inference budget, and evaluator. Parameter error alone is not substituted for evaluation error. The NExt extrapolation and recovery schedule described in Sections 4.1--4.3 and 5.1 motivates this comparison Low-rank optimization trajectories modeling for LLM RLVR acceleration[chen2026lowrank], but the paper does not state this regret definition.
Example. Counterexample: early low-rank agreement does not determine continuation [ftip-008A]AGENTDRAFTED
Example. Counterexample: early low-rank agreement does not determine continuation [ftip-008A]AGENTDRAFTED
Let \(e_1=(1,0)^{\mathsf T}\) and \(e_2=(0,1)^{\mathsf T}\) be the standard basis vectors of \(\mathbb R^2\). In a two-dimensional matrix chart, set \(P=e_1e_1^{\mathsf T}\) and \(Q=e_2e_2^{\mathsf T}\). Two paths share the entire observed history \[ W_0=0,\qquad W_1=P,\qquad W_2=2P. \] Every observed local difference is the same rank-one matrix \(P\). The paths then fork: path A takes \(W_3^A=3P\), whereas path B takes \(W_3^B=2P+Q\). Each next local difference is again rank one.
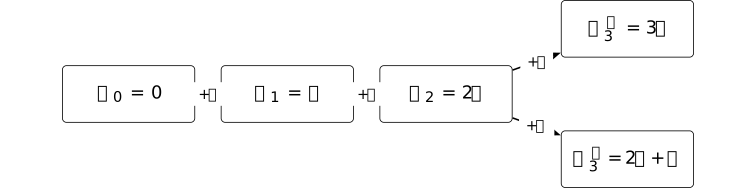
A deterministic history-only forecaster must return the same matrix \(\widehat W_3\) in both worlds. Since \(\|W_3^A-W_3^B\|_F=\|P-Q\|_F=\sqrt {2}\), the triangle inequality forces its Frobenius error to be at least \(1/\sqrt {2}\) on one continuation. Low-rank early motion therefore does not identify the next subspace or the next checkpoint.
Remark. Compression of a charted path is not capability acquisition [ftip-008B]AGENTDRAFTED
Remark. Compression of a charted path is not capability acquisition [ftip-008B]AGENTDRAFTED
NExt extracts global, local, and target differences from LoRA checkpoint matrices, keeps leading singular factors, learns a nonlinear predictor, jumps in that parameter chart, and resumes RLVR [chen2026lowrank, Sections 3.2, 4.1--4.3, and 5.1]. Its reported results are empirical; the paper states no theorem that a leading subspace remains stable or that a forecast preserves a policy.
The quantities in Definition [ftip-0086]--Definition [ftip-0089] separate four tests. Squared singular-energy share concerns one matrix, spectral gap controls whether its leading subspace is identifiable, projector drift compares those subspaces over time, and path-emulation regret returns to fixed independent evaluation. None, by itself, is evidence that new feedback was acquired or that a new capability was learned. Such a claim must use a declared post-training gain such as Definition [ftip-005F] and must charge forecast training, the parameter jump, and recovery updates.
Alignment gain and preference information [ftip-008E]AGENTDRAFTED
Alignment gain and preference information [ftip-008E]AGENTDRAFTED
Two finite models ask different questions about post-training. The first assumes an exact KL-regularized optimizer and characterizes the reward gain that its exponential tilt can produce. The second asks what ordinal comparisons reveal when post-training may reroute a fixed set of response circuits.
Neither source model is a general account of neural post-training. The first assumes exact optimization of a declared scalar reward. The second is a stylized routing model with a fixed circuit set. Extending the KL identity to an approximate optimizer requires further analysis. Extending the ordinal routing conclusion to a changing circuit set requires additional assumptions on that change.
Finite KL-regularized alignment [ftip-008F]AGENTDRAFTED
Finite KL-regularized alignment [ftip-008F]AGENTDRAFTED
This subsection studies an exact, finite optimization model. A reference law is exponentially tilted by a declared scalar reward. In this setting, reward gain admits two exact descriptions: a Jeffreys-divergence identity and a covariance under the reference law.
The statements do not model approximate optimization, neural training cost, reward validity, or independent capability evaluation.
Remark. Exact optimization on a finite response set [ftip-008G]AGENTDRAFTED
Remark. Exact optimization on a finite response set [ftip-008G]AGENTDRAFTED
Theorems 1 and 2 of the v1 preprint [paes2026theoretical] concern an exactly optimal KL-regularized policy and a fixed query. On a finite response set, their expectations and normalizers are ordinary finite sums.
These exact identities do not establish a comparison among best-of-\(N\), PPO, and GRPO, or a general guarantee for proxy rewards and reward ensembles. Those questions require assumptions beyond exact optimization of one reward.
Notation. Translating the alignment source notation [ftip-008H]AGENTDRAFTED
Notation. Translating the alignment source notation [ftip-008H]AGENTDRAFTED
The source writes \(\lambda >0\) for the KL penalty. Here we write \(\beta >0\), matching the DPO notation in Notation [ftip-003M]--Definition [ftip-003O]. This avoids collision with the generalized-advantage parameter in Definition [ftip-003E] and the protocol law in Definition [ftip-007Q].
The source's gain \(\Delta (r,r')\) is written \(G_p(r;s)\): \(r\) is the reward used to tilt the reference law \(p\), while \(s\) is the reward used to evaluate the tilted law. This avoids collision with both the simplex notation \(\Delta (X)\) of Notation [ftip-000A] and the paired DPO margin of Notation [ftip-003M]. For a finite set \(\mathcal Y\), a law \(p\in \Delta (\mathcal Y)\), and functions \(f,g:\mathcal Y\to \mathbb R\), set
\[ \operatorname {Cov}_p(f,g) =\mathbb E_{y\sim p}[f(y)g(y)] -\mathbb E_{y\sim p}[f(y)]\, \mathbb E_{y\sim p}[g(y)]. \]
Definition. Finite KL-alignment instance [ftip-008I]AGENTDRAFTED
Definition. Finite KL-alignment instance [ftip-008I]AGENTDRAFTED
A finite KL-alignment instance consists of a nonempty finite response set \(\mathcal Y\), a reference law \(p\in \Delta (\mathcal Y)\), a penalty \(\beta >0\), and finite real functions \(r,s:\mathcal Y\to \mathbb R\). The reference support is
\[ S_p=\{y\in \mathcal Y:p(y)>0\}. \]A prompt is fixed and suppressed. The function \(r\) determines the alignment update; \(s\) measures its result. They may coincide, but they need not. Finiteness makes every exponential weight and expectation below finite.
These objects specialize the fixed-query setting in [paes2026theoretical, Section 2, equations (2.1)--(2.2)]; they are not a definition of alignment in general.
Definition. Exponential weight and partition function [ftip-008J]AGENTDRAFTED
Definition. Exponential weight and partition function [ftip-008J]AGENTDRAFTED
For a finite KL-alignment instance, define the exponential weight and partition function by
\[ a_r(y)=\exp \left (\frac {r(y)}{\beta }\right ), \qquad Z_r=\mathbb E_{y\sim p}[a_r(y)]. \]Every \(a_r(y)\) is finite and strictly positive. Since \(p\) is a probability law on a nonempty finite set, \(0<Z_r<\infty \).
This weight and normalizer are the fixed-query form of [paes2026theoretical, Equation (2.2)].
Definition. Aligned law in finite-source notation [ftip-008K]AGENTDRAFTED
Definition. Aligned law in finite-source notation [ftip-008K]AGENTDRAFTED
The aligned law induced by \(r\) is \(q_r\in \Delta (\mathcal Y)\) given by
\[ q_r(y)=\frac {p(y)a_r(y)}{Z_r}. \]Normalization follows from the definition of \(Z_r\). Moreover, \(q_r(y)>0\) exactly when \(p(y)>0\). This is the finite notation for the same exponential-tilt optimizer stated in Definition [ftip-003O]; support preservation was proved in Theorem [ftip-007C].
This formula is [paes2026theoretical, Equation (2.2)]. It assumes the exact optimizer, not an iterate returned by a particular training algorithm.
Definition. Cross-reward gain under an alignment reward [ftip-008L]AGENTDRAFTED
Definition. Cross-reward gain under an alignment reward [ftip-008L]AGENTDRAFTED
The cross-reward gain from aligning with \(r\) and evaluating with \(s\) is
\[ G_p(r;s) =\mathbb E_{y\sim q_r}[s(y)] -\mathbb E_{y\sim p}[s(y)]. \]The semicolon records two roles. Its left argument changes the response law; its right argument scores both laws. Thus \(G_p(r;s)\) is not an independent evaluation unless \(s\) has separately been declared to serve that role.
This is the finite notation for \(\Delta (r,r')\) in Theorem 2, equation (3.4), of Theoretical limits of language model alignment[paes2026theoretical].
Definition. Jeffreys divergence [ftip-008M]AGENTDRAFTED
Definition. Jeffreys divergence [ftip-008M]AGENTDRAFTED
For probability laws \(p\) and \(q\) for which both terms are finite, their Jeffreys divergence is
\[ J(p,q) =D_{\mathrm {KL}}(p\Vert q) +D_{\mathrm {KL}}(q\Vert p). \]The KL divergence and its argument order are defined in Definition [ftip-006X]. Unlike either directed term, \(J(p,q)=J(q,p)\). In the finite tilt of Definition [ftip-008K], \(p\) and \(q_r\) have the same support, so both terms are finite.
Lemma. Log-density ratio of the exact tilt [ftip-008N]AGENTDRAFTED
Lemma. Log-density ratio of the exact tilt [ftip-008N]AGENTDRAFTED
For every \(y\in S_p\), the aligned law satisfies
\[ \log \frac {q_r(y)}{p(y)} =\frac {r(y)}{\beta }-\log Z_r. \]
Proof.
Proof.
On \(S_p\), both \(p(y)\) and \(q_r(y)\) are positive. Dividing the formula of Definition [ftip-008K] by \(p(y)\) and taking logarithms gives the identity.
This is equation (B.1) followed by the logarithmic step in [paes2026theoretical, Appendix B.1, equations (B.1)--(B.2)].
Theorem. Exact reward gain equals scaled Jeffreys divergence [ftip-008O]AGENTDRAFTED
Theorem. Exact reward gain equals scaled Jeffreys divergence [ftip-008O]AGENTDRAFTED
For a finite KL-alignment instance,
\[ G_p(r;r)=\beta J(p,q_r). \]
Proof.
Proof.
Rearranging Lemma [ftip-008N] gives \(r(y)=\beta \log (q_r(y)/p(y))+\beta \log Z_r\) on the common support. Taking expectation first under \(q_r\) and then under \(p\) yields
\[ \begin {aligned} \mathbb E_{q_r}[r] &=\beta D_{\mathrm {KL}}(q_r\Vert p)+\beta \log Z_r,\\ \mathbb E_p[r] &=-\beta D_{\mathrm {KL}}(p\Vert q_r)+\beta \log Z_r. \end {aligned} \]Subtracting cancels the common normalizer and gives the result.
This is the finite form of [paes2026theoretical, Theorem 1, equation (3.2), with proof in Appendix B.1].
Remark. What the Jeffreys identity does and does not identify [ftip-008P]AGENTDRAFTED
Remark. What the Jeffreys identity does and does not identify [ftip-008P]AGENTDRAFTED
The identity Theorem [ftip-008O] is an equality inside one declared model. It says that exact gain in the optimizing reward equals a symmetric divergence from the reference law. It does not say that a larger divergence improves a different utility, nor that a training algorithm reaches the exact tilt.
The identity accounts for neither rollout and update work nor the cost of obtaining \(r\). Consequently it is not, by itself, a bound on the costed post-training potential of Definition [ftip-005M].
Theorem. Cross-reward gain is a base-law covariance [ftip-008Q]AGENTDRAFTED
Theorem. Cross-reward gain is a base-law covariance [ftip-008Q]AGENTDRAFTED
For a finite KL-alignment instance,
\[ G_p(r;s) =\operatorname {Cov}_p\left (s,\frac {a_r}{Z_r}\right ). \]
Proof.
Proof.
The aligned expectation can be written under the reference law as \(\mathbb E_{q_r}[s]=\mathbb E_p[s a_r/Z_r]\). Also \(\mathbb E_p[a_r/Z_r]=1\). Substituting these two identities into Definition [ftip-008L] gives the covariance defined in Notation [ftip-008H].
This is the finite form of Theorem 2, equation (3.4), in Theoretical limits of language model alignment[paes2026theoretical]. Its proof is in Appendix B.1, equations (B.5)--(B.7).
Remark. The covariance is predictive only for a declared reward [ftip-008R]AGENTDRAFTED
Remark. The covariance is predictive only for a declared reward [ftip-008R]AGENTDRAFTED
The identity Theorem [ftip-008Q] expresses exact tilted-law gain using expectations under \(p\). This makes the population quantity accessible from the reference law in principle. A finite-sample estimator still needs its own sampling law, moment assumptions, and error analysis.
The formula also remains indexed by both \(r\) and \(s\). It cannot turn a proxy reward into an independent utility. If \(s=r\), it measures improvement in the same quantity that defined the exact optimizer; if \(s\ne r\), its sign is determined by the displayed covariance.
Example. A two-response alignment identity [ftip-008S]AGENTDRAFTED
Example. A two-response alignment identity [ftip-008S]AGENTDRAFTED
Take \(\mathcal Y=\{a,b\}\), \(p=(1/2,1/2)\), \(\beta =1\), and \(r(a)=0\), \(r(b)=\log 3\). Exponential weighting changes the reference law as follows.
The reward gain is
\[ G_p(r;r) =\left (\frac 34-\frac 12\right )\log 3 =\frac 14\log 3. \]Direct calculation gives
\[ \begin {aligned} D_{\mathrm {KL}}(q_r\Vert p) &=\frac 14\log \frac 12+\frac 34\log \frac 32,\\ D_{\mathrm {KL}}(p\Vert q_r) &=\frac 12\log 2+\frac 12\log \frac 23, \end {aligned} \]whose sum is \(\frac 14\log 3\). Thus the example checks Theorem [ftip-008O] exactly; it is not an empirical alignment result.
Corollary. Averaging the fixed-query identity over prompts [ftip-008T]AGENTDRAFTED
Corollary. Averaging the fixed-query identity over prompts [ftip-008T]AGENTDRAFTED
Let \(\mathcal X\) be finite with prompt law \(\mu \). For each \(x\in \mathcal X\), let \(p_x\), \(r_x\), and \(q_{r_x}\) be a finite KL-alignment instance with the same penalty \(\beta >0\). Then
\[ \sum _{x\in \mathcal X}\mu (x)G_{p_x}(r_x;r_x) =\beta \sum _{x\in \mathcal X}\mu (x)J(p_x,q_{r_x}). \]
Proof.
Proof.
Apply Theorem [ftip-008O] at each prompt and take the finite \(\mu \)-weighted sum.
The source theorem is stated for each fixed query. This corollary performs only finite averaging; it does not introduce a shared neural parameterization across prompts.
Lemma. Additive reward shifts leave the aligned law unchanged [ftip-008U]AGENTDRAFTED
Lemma. Additive reward shifts leave the aligned law unchanged [ftip-008U]AGENTDRAFTED
For constants \(c,d\in \mathbb R\),
\[ q_{r+c}=q_r, \qquad G_p(r+c;s+d)=G_p(r;s). \]
Proof.
Proof.
The shifted weight is \(a_{r+c}=e^{c/\beta }a_r\), while its partition function is \(Z_{r+c}=e^{c/\beta }Z_r\); the common factor cancels in the aligned law. Adding \(d\) to the evaluation reward adds \(d\) to both expectations in the gain, so it also cancels.
This finite lemma records the same prompt-dependent additive non-identifiability that appears in the DPO reparameterization of Definition [ftip-003P].
Remark. A penalty coefficient is not a hard KL budget [ftip-008V]AGENTDRAFTED
Remark. A penalty coefficient is not a hard KL budget [ftip-008V]AGENTDRAFTED
For fixed \(\beta \), the exponential tilt solves the penalized problem
\[ \max _{q\in \Delta (\mathcal Y)} \left \{\mathbb E_q[r] -\beta D_{\mathrm {KL}}(q\Vert p)\right \} \]under the conventions of Definition [ftip-008I]. This is not the same specification as choosing a number \(\kappa \) and solving
\[ \max _q\mathbb E_q[r] \quad \text {subject to}\quad D_{\mathrm {KL}}(q\Vert p)\leq \kappa . \]A Lagrange multiplier can relate the two problems when the relevant duality and activity conditions hold. The coefficient \(\beta \) alone does not declare a hard budget, and the identities Theorem [ftip-008O]--Theorem [ftip-008Q] do not supply those conditions.
Remark. Fixed-query identities and their assumptions [ftip-008W]AGENTDRAFTED
Remark. Fixed-query identities and their assumptions [ftip-008W]AGENTDRAFTED
The source setup writes rewards as \(r(\mathbf x,\mathbf y)\), while the display of Theorem 1 reverses the two arguments in places. This subsection uses the setup order and then suppresses the fixed prompt. The source also moves between a dataset-level penalized objective and fixed-query identities. The finite-averaging result Corollary [ftip-008T] makes that step explicit.
The identities specialize Theoretical limits of language model alignment[paes2026theoretical] to a finite response set. They require no extension to the full sequence space.
Finally, exact exponential tilting is a distributional optimizer. It does not account for rollout, gradient, optimizer, or systems cost, and it does not show that PPO, GRPO, DPO, or any frontier training run attains the displayed law. Applying the identities to a training run therefore requires a separate argument that its output law is the exact optimizer.
Preference-feedback distortion [ftip-008X]AGENTDRAFTED
Preference-feedback distortion [ftip-008X]AGENTDRAFTED
A finite routing model supports preference-distortion lower bounds in Sections 2--3 and Appendix A of The limits of preference data for post-training[zhao2025limits]. Cardinal queries permit a different guarantee under the hypotheses of Peeking behind the ordinal curtain: Improving distortion via cardinal queries[amanatidis2021peeking].
Both comparisons depend on the queries, circuits, routing maps, utility, feedback profile, algorithm, and comparator class. The noiseless and Bradley--Terry bounds retain those model restrictions.
Remark. The routing-model assumption behind preference limits [ftip-008Y]AGENTDRAFTED
Remark. The routing-model assumption behind preference limits [ftip-008Y]AGENTDRAFTED
The routing model and preference limits below are based on the v1 preprint The limits of preference data for post-training[zhao2025limits]. It models a pretrained system as a finite collection of response circuits plus learned maps that route queries to those circuits. Post-training changes the routing maps while retaining the circuit collection.
The noiseless lower bound is proved here under explicit pointwise response separation and a deterministic preference-only learner, whose returned router may be stochastic. Its finite partition estimate and cardinal-utility construction give a restricted reconstruction of the source rate; the proof does not establish a randomized-learner extension.
The routing model is a source assumption, not an architectural theorem about language models. In particular, its lower bounds do not prove that real post-training creates no circuits, that a neural network decomposes into the displayed objects, or that every preference-learning algorithm obeys the same bound outside this model.
Notation. Notation for the finite preference model [ftip-008Z]AGENTDRAFTED
Notation. Notation for the finite preference model [ftip-008Z]AGENTDRAFTED
The finite preference model uses the following symbols, corresponding to the notation of The limits of preference data for post-training[zhao2025limits]:
\[ \mathcal Q\mapsto Q,\qquad \mathcal R\mapsto Y,\qquad \mathcal S_0\mapsto C_0,\qquad \mathcal Z\mapsto H, \]\[ \Phi \mapsto \mathfrak E,\qquad \mathcal D\mapsto \mu _Q,\qquad M\mapsto \mathfrak m. \]Thus \(H\) denotes the source's finite internal-representation set, not a public interaction history. The family \(\mathfrak E\) contains admissible query encoders and is unrelated to the costed potential \(\Phi \) of Definition [ftip-005M].
Definition. Queries, responses, and retained circuits [ftip-0090]AGENTDRAFTED
Definition. Queries, responses, and retained circuits [ftip-0090]AGENTDRAFTED
Following the formal model in Section 2 of The limits of preference data for post-training[zhao2025limits], let \(Q\) be a finite nonempty query set and \(Y\) a response set. A response circuit is a function \(c:Q\to Y\). The finite nonempty set \(C_0\) contains the circuits retained from the pretrained model.
The word ``circuit'' is source terminology for this abstract function. No claim is made here that an element of \(C_0\) is localized in a neural network or corresponds to one human-named capability.
Definition. Query representation and circuit routing [ftip-0091]AGENTDRAFTED
Definition. Query representation and circuit routing [ftip-0091]AGENTDRAFTED
Let \(H\) be a finite nonempty representation set and \(\mathfrak E\subseteq H^Q\) a finite nonempty family of admissible encoders. A query encoder is \(e\in \mathfrak E\). A circuit router is a map
\[ h:H\longrightarrow \Delta (C_0). \]For a query \(\xi \in Q\), the composition \(h(e(\xi ))\) is a law on the retained circuits. Sampling \(c\sim h(e(\xi ))\) and returning \(c(\xi )\) gives the response law. These are the two routing components in the source model [zhao2025limits, Section 2, ``Formal model''].
Definition. Pretrained and post-trained routing models [ftip-0092]AGENTDRAFTED
Definition. Pretrained and post-trained routing models [ftip-0092]AGENTDRAFTED
A routing model is a triple \(\mathfrak m=(e,h,C_0)\) with the types fixed in Definition [ftip-0090]--Definition [ftip-0091]. The pretrained model is \(\mathfrak m_0=(e_0,h_0,C_0)\). In the source intervention, a post-trained model may replace \(e_0\) and \(h_0\), but it retains exactly \(C_0\).
Write \(\mathfrak m(\xi )\) for the random response obtained by sampling \(c\sim h(e(\xi ))\) and returning \(c(\xi )\). The source sometimes writes this as though the router selected a circuit rather than a distribution; the stochastic reading follows its declared codomain \(\Delta (C_0)\).
Definition. Utility and the uniform query law [ftip-0093]AGENTDRAFTED
Definition. Utility and the uniform query law [ftip-0093]AGENTDRAFTED
The source fixes the uniform probability law \(\mu _Q\) on \(Q\) and a utility function
\[ u:Q\times Y\longrightarrow \mathbb R. \]For a routing model \(\mathfrak m\), its expected utility is
\[ U_u(\mathfrak m) =\mathbb E_{\xi \sim \mu _Q} \mathbb E\left [u\left (\xi ,\mathfrak m(\xi )\right )\mid \xi \right ]. \]This is the outcome objective in [zhao2025limits, Section 2, ``Outcome-based optimization with preference data'']. It is an assumed cardinal utility, not something ordinal comparisons directly reveal.
Definition. Complete noiseless ordinal preference profile [ftip-0094]AGENTDRAFTED
Definition. Complete noiseless ordinal preference profile [ftip-0094]AGENTDRAFTED
Assume that distinct retained circuits never tie at a query. For each \(\xi \in Q\), utility then induces a strict comparison by
\[ c_i\succ _{\xi ,u}c_j \quad \Longleftrightarrow \quad u\left (\xi ,c_i(\xi )\right ) >u\left (\xi ,c_j(\xi )\right ). \]The complete noiseless ordinal profile is \(\succ _u=(\succ _{\xi ,u})_{\xi \in Q}\). The source gives the learner unlimited, unbiased access to every such comparison [zhao2025limits, Section 2, final paragraph]. Utilities with ties require a separately declared deterministic tie-break; the lower bounds below use the source's tie-free constructions.
Remark. Full preference data and an online oracle expose the same source information [ftip-0095]AGENTDRAFTED
Remark. Full preference data and an online oracle expose the same source information [ftip-0095]AGENTDRAFTED
Within this finite model, a table containing every comparison in \(\succ _u\) and a noiseless online oracle that answers every possible query expose the same ordinal information. The source deliberately grants this ideal access so that its obstruction is not caused by finite sampling or an offline split [zhao2025limits, Section 2].
This equivalence does not price the number of queries, labeler time, or adaptivity. It therefore cannot be transferred to a finite-feedback protocol without a separate query-complexity statement.
Definition. Preference-only post-training algorithm and attainable route class [ftip-0096]AGENTDRAFTED
Definition. Preference-only post-training algorithm and attainable route class [ftip-0096]AGENTDRAFTED
A preference-only post-training algorithm \(\mathcal A\) maps the pretrained routing model and the complete profile to
\[ \mathfrak m_{\mathcal A}(u) =\mathcal A(\mathfrak m_0,\succ _u). \]The deterministic comparator class displayed in the source theorems is
\[ \mathcal M_{\rm det}(C_0) =\left \{(e,h,C_0):e\in \mathfrak E, h:H\to C_0\right \}. \]The source's formal model initially permits stochastic routers \(h:H\to \Delta (C_0)\), but its theorem comparator uses deterministic \(h:H\to C_0\). The comparator class is therefore the displayed deterministic class.
Definition. Multiplicative post-training distortion [ftip-0097]AGENTDRAFTED
Definition. Multiplicative post-training distortion [ftip-0097]AGENTDRAFTED
Let \(\mathcal B\) be any post-training algorithm with output \(\mathfrak m_{\mathcal B}(u)\) under the feedback law induced by \(u\). When the denominator is positive, define its multiplicative post-training distortion by
\[ \operatorname {Dist}_u(\mathcal B;\mathfrak m_0) =\frac { \max _{\mathfrak m^*\in \mathcal M_{\rm det}(C_0)}U_u(\mathfrak m^*) }{ U_u(\mathfrak m_{\mathcal B}(u)) }. \]If the numerator is positive and the denominator is zero, set the ratio to \(+\infty \). The source lower bounds construct bounded nonnegative utilities for which the comparison is well defined [zhao2025limits, Equation (2) and Appendix A]. Distortion measures loss relative to the declared comparator class; it is not an absolute capability score.
Definition. Borda count [ftip-0098]AGENTDRAFTED
Definition. Borda count [ftip-0098]AGENTDRAFTED
Let \(m=|C_0|\), and suppose each \(\succ _{\xi ,u}\) is a strict total order on \(C_0\). If \(\operatorname {rank}_{\succ _{\xi ,u}}(c)\) places the most preferred circuit at rank one, its Borda score is
\[ B_{\xi }(c)=m-\operatorname {rank}_{\succ _{\xi ,u}}(c). \]The Borda-count choice is any circuit in
\[ \operatorname *{arg\,max}_{c\in C_0} \sum _{\xi \in Q}B_{\xi }(c). \]This is [zhao2025limits, Definition 3.1]. The source cites a prior equivalence between a standard RLHF model and Borda count; the definition here does not assert that every RLHF implementation is a Borda rule.
Example. A compromise circuit can maximize utility without winning Borda count [ftip-0099]AGENTDRAFTED
Example. A compromise circuit can maximize utility without winning Borda count [ftip-0099]AGENTDRAFTED
Example 3.2 of The limits of preference data for post-training[zhao2025limits] prints only \(a\geq 0\) and \(2a<b\), but those conditions do not force its stated rankings or Borda totals. Sufficient conditions are \(0<a<1/2\) and \(2a<b<1\). Take three queries, three circuits, and a singleton representation set, so every query must use one common circuit. Set
\[ \begin {array}{c|ccc} &c_A&c_B&c_C\\ \hline \xi _1&1&0&1-a\\ \xi _2&1&0&1-a\\ \xi _3&0&1&b \end {array} \]These inequalities give the rankings \(c_A\succ c_C\succ c_B\) for \(\xi _1,\xi _2\) and \(c_B\succ c_C\succ c_A\) for \(\xi _3\). Hence the Borda totals are \((4,2,3)\), so the ordinal rule selects \(c_A\). The utility totals are \((2,1,2-2a+b)\). Since \(2a<b\), circuit \(c_C\) has strictly greater total utility than \(c_A\).
This finite example isolates information lost by ranking. The compromise circuit is never first for an individual query, yet its aggregate utility is largest. It does not show that Borda is always suboptimal or that a neural model must collapse all queries to one representation.
Theorem. Noiseless preference distortion for deterministic learners [ftip-009A]AGENTDRAFTED
Theorem. Noiseless preference distortion for deterministic learners [ftip-009A]AGENTDRAFTED
Let \(Q,H\) be nonempty finite sets, let \(\varnothing \neq \mathfrak E\subseteq H^Q\) be finite, and let \(C_0=\{c_1,\ldots ,c_m\}\) be a nonempty finite set of deterministic maps \(Q\to Y\). Write \(N=|Q|\), \(r=|H|\), \(p=|\mathfrak E|\) and \(m=|C_0|\). The query law is uniform on \(Q\). Call \(C_0\) pointwise response-separating when
\[ c_i\neq c_j\quad \Longrightarrow \quad c_i(q)\neq c_j(q) \qquad (q\in Q). \]Assume this separation. Let \(\mathcal A\) be a deterministic preference-only learner: from a pretrained model \(\mathfrak m_0\) and the complete strict ordinal profile, it returns \((e,h,C_0)\) with \(e\in \mathfrak E\) and a possibly stochastic router \(h:H\to \Delta (C_0)\). The comparator class is exactly \(\mathcal M_{\rm det}(C_0)\) of Definition [ftip-0096], including every map \(H\to C_0\) for each \(e\in \mathfrak E\).
For every such pretrained model and learner there exists \(u:Q\times Y\to [0,1]\), inducing a strict profile, such that
\[ \sum _{j=1}^m u(q,c_j(q))=1\quad (q\in Q), \]\[ R_{Q,\mathfrak E,H}=\frac {N}{\sqrt {N(r+\log p)}+r}, \]\[ \operatorname {Dist}_u(\mathcal A;\mathfrak m_0) \geq \frac 1{80}\min \{\sqrt m,R_{Q,\mathfrak E,H}\}. \]Logarithms are natural. Utility averages over the uniform query and the learner's router draw as in Definition [ftip-0093]. The comparator maximum exists because its class is finite and nonempty. It is positive for the normalized utilities above: some constant-circuit route has mean at least \(1/m\). A zero learner utility therefore gives distortion \(+\infty \), with no \(0/0\) case.
Proof.
Proof.
First, for every normalized nonnegative utility, the comparator value is at least the learner value. Keep the learner's representation map and, on each fiber, choose a circuit maximizing its total utility there. That deterministic choice dominates the stochastic mixture and belongs to the comparator class. Thus distortion is at least one.
Put
\[ \begin {aligned} D&=\sqrt {Nr}+\sqrt {\frac N2\log (4p)},& B&=\sqrt {N(r+\log p)},\\ T&=\min \{\sqrt m,R_{Q,\mathfrak E,H}\},& x&=\min \{\sqrt m,N/(2D)\}. \end {aligned} \]Since \((\log 4)/2<1\leq r\) and \(\log p\geq 0\), we have \(D\leq 2B\). Consequently \(N/(2D)\geq N/(4B)\geq R_{Q,\mathfrak E,H}/4\) and \(x\geq T/4\). Every denominator is positive.
If \(m=1\), assign utility one to the sole circuit response at every query. Distortion is one and \(T\leq 1\). If \(m\geq 2\) but \(x<2\), assign the same strict normalized values \(2(m-j)/(m(m-1))\) to the circuits in index order at every query. Distortion is at least one and \(T<8\), which proves the claimed bound. Extend both assignments by zero to all other responses.
In the remaining case set \(k=\lfloor x\rfloor \). Then
\[ 2\leq k\leq \sqrt m,\qquad kD\leq N/2, \qquad k\geq x/2\geq T/8. \]Write \([k]=\{1,\ldots ,k\}\) and fix a map \(f:Q\to [k]\) supplied by Lemma [ftip-009C]. At a query with label \(i=f(q)\), fix the strict order putting \(c_i\) first and the remaining circuits in increasing index order. Let \(\operatorname {rank}_i(j)\in \{1,\ldots ,m\}\) be the position of \(c_j\), with the first circuit at rank one, and define
\[v_i(j)=\frac {2(m-\operatorname {rank}_i(j))}{m(m-1)}.\]These values decrease strictly in the fixed order, sum to one and lie in \([0,2/m]\). The ordinal profile is now fixed independently of the learner's output. Run the deterministic learner on this profile and \(\mathfrak m_0\), obtaining \((e,h,C_0)\). Write \(h_z(j)=h(z)(c_j)\) for the probability of circuit \(c_j\) at representation \(z\). For each \(z\in H\), choose \(i_z\in [k]\) minimizing \(h_z(j)\) over \(j\in [k]\), breaking ties by index. Since \(\sum _{j=1}^k h_z(j)\leq 1\), we have \(h_z(i_z)\leq1/k\).
Let \(A=\{q:f(q)=i_{e(q)}\}\) and \(S=|A|\). The lower partition bound gives
\[ S=\sum _zX_{z,i_z}\geq \sum _z\min _{j\in [k]}X_{z,j} \geq N/k-D\geq N/(2k). \]Fix \(\epsilon =1/4\). For \(i=f(q)\), assign
\[ u(q,c_j(q))= \begin {cases} (1-\epsilon )\mathbf 1_{j=i}+\epsilon v_i(j),&q\in A,\\ (1-\epsilon )/m+\epsilon v_i(j),&q\notin A. \end {cases} \]Each row is nonnegative and sums to one. On selected queries the added peak favors the already highest-ranked circuit; on the other queries the same constant is added to every circuit. Hence every row induces exactly the fixed strict order. Pointwise response separation makes these assignments well-defined on \(Q\times Y\); assign zero to responses outside the attained circuit responses. Because the final utility has the unchanged ordinal profile, the deterministic learner returns the same \((e,h,C_0)\).
Write \(W=NU\) for total utility. A selected query gives the learner at most \((1-\epsilon )/k+2\epsilon/m\); any other query gives at most \((1-\epsilon )/m+2\epsilon/m\). Averaging over the stochastic router yields
\[ W_{\mathcal A} \leq (1-\epsilon )S/k+(1-\epsilon )(N-S)/m+2\epsilon N/m \leq S/k+2N/m. \]Choose the deterministic comparator \(e^*=e\) and \(h^*(z)=c_{i_z}\). It belongs to the declared class, attains utility at least \(1-\epsilon \geq1/2\) on each selected query and nonnegative utility elsewhere. Thus its total utility is at least \(S/2\). If learner utility is zero the bound follows. Otherwise, using \(S\geq N/(2k)\) and \(k^2\leq m\),
\[ \begin {aligned} \operatorname {Dist}_u &\geq \frac {S/2}{S/k+2N/m} =\frac {k}{2(1+2kN/(mS))}\\ &\geq \frac {k}{2(1+4k^2/m)} \geq \frac {k}{10}\geq \frac {T}{80}. \end {aligned} \]Appendix Theorem A.1 of The limits of preference data for post-training[zhao2025limits] states the corresponding rate for its routing model. Its displayed balancing parameter retains \(\log N\) factors that are absent from its final rate; the second-moment partition bound in Lemma [ftip-009C] supplies a separate argument for the stated restricted model. Its index-based perturbation on queries outside the selected group need not preserve their prescribed favorite; the query-dependent rank weights used here preserve it. When circuits collide at a query, a circuitwise prescription need not define a response utility; pointwise separation excludes that issue.
The utility is a worst-case existential choice for each fixed learner. The proof permits stochastic inference, but it does not cover internal learner randomness: a utility chosen after a realized random output need not be one utility valid before the learner's random draw. No claim about response-colliding circuits or the separate noisy-preference bound follows.
Corollary. A square-root corollary under explicit query growth [ftip-009B]AGENTDRAFTED
Corollary. A square-root corollary under explicit query growth [ftip-009B]AGENTDRAFTED
Under all hypotheses of Theorem [ftip-009A], including a deterministic preference-only learner and pointwise response separation, assume
\[R_{Q,\mathfrak E,H}\geq \sqrt {|C_0|}.\]For every pretrained model and every such learner, the utility supplied by that theorem satisfies
\[ \operatorname {Dist}_u(\mathcal A;\mathfrak m_0) \geq \frac 1{80}\sqrt {|C_0|}. \]
Proof.
Proof.
The displayed growth condition makes the minimum in Theorem [ftip-009A] equal to \(\sqrt {|C_0|}\).
Theorem 3.3 of The limits of preference data for post-training[zhao2025limits] gives a square-root rate in its large-query regime. The explicit condition above gives a finite regime for the reconstructed theorem with its stated learner and response assumptions.
Lemma. A simultaneous finite partition bound [ftip-009C]AGENTDRAFTED
Lemma. A simultaneous finite partition bound [ftip-009C]AGENTDRAFTED
Let \(Q,H\) be nonempty finite sets with \(N=|Q|\) and \(r=|H|\), and let \(\mathfrak E\subseteq H^Q\) be nonempty and finite with \(p=|\mathfrak E|\). For every integer \(k\geq 1\), there is a map \(f:Q\to [k]\) such that, simultaneously for every \(e\in \mathfrak E\),
\[ \begin {aligned} \sum _{z\in H}\max _{j\in [k]}X_{z,j}&\leq \frac Nk+D,\\ \sum _{z\in H}\min _{j\in [k]}X_{z,j}&\geq \frac Nk-D, \end {aligned} \]where \([k]=\{1,\ldots ,k\}\), logarithms are natural, and
\[ X_{z,j}=|\{q\in Q:e(q)=z,\ f(q)=j\}|, \qquad D=\sqrt {Nr}+\sqrt {\frac N2\log (4p)}. \]
Proof.
Proof.
Choose the labels \(f(q)\) independently and uniformly from \([k]\). Fix \(e,z\), write \(n_z=|e^{-1}(z)|\), and put \(a_j=X_{z,j}-n_z/k\). Each occupancy has variance \(n_z(1/k)(1-1/k)\), so
\[\mathbb E\sum _{j=1}^k a_j^2=n_z(1-1/k).\]The pointwise maximum and minimum satisfy
\[ \begin {aligned} \max _jX_{z,j}&\leq n_z/k+\|a\|_2,\\ \min _jX_{z,j}&\geq n_z/k-\|a\|_2. \end {aligned} \]Jensen's inequality gives \(\mathbb E\|a\|_2\leq \sqrt {n_z(1-1/k)}\). Summing over \(z\) and applying Cauchy--Schwarz yields
\[ \begin {aligned} \mathbb E\sum _z\max _jX_{z,j}&\leq N/k+\sqrt {Nr(1-1/k)},\\ \mathbb E\sum _z\min _jX_{z,j}&\geq N/k-\sqrt {Nr(1-1/k)}. \end {aligned} \]Changing one label changes only one representation group: one occupancy decreases by one and another increases by one. Its maximum and its minimum each change by at most one. Thus both sums have bounded differences with all \(N\) constants equal to one. McDiarmid's inequality, also used in Appendix A.1 of The limits of preference data for post-training[zhao2025limits], bounds each relevant one-sided deviation of size \(t\) by \(\exp (-2t^2/N)\).
Choose \(t=\sqrt {(N/2)\log (4p)}\). A union bound over both tails and all \(p\) representations gives total failure probability at most
\[2p\exp (-2t^2/N)=\frac 12<1.\]At least one deterministic labeling satisfies both claimed bounds, since \(\sqrt {Nr(1-1/k)}\leq \sqrt {Nr}\). Empty representation fibers have all occupancies zero and require no exception.
The bound uses a second-moment estimate in place of the occupancy estimate in source Lemma A.2. The chosen labeling depends only on \(Q,H,\mathfrak E,k\); its existence uses proof randomness and does not assume randomness in the learning algorithm.
Definition. Bradley--Terry preference from a score map [ftip-009D]AGENTDRAFTED
Definition. Bradley--Terry preference from a score map [ftip-009D]AGENTDRAFTED
Fix a query \(\xi \) and nonnegative circuit scores \(a_{\xi ,c}\geq 0\) such that \(a_{\xi ,c_i}+a_{\xi ,c_j}>0\) for every compared pair. The Bradley--Terry comparison law is
\[ \Pr (c_i\succ _{\xi }c_j) =\frac {a_{\xi ,c_i}} {a_{\xi ,c_i}+a_{\xi ,c_j}}. \]Only score ratios are identified: multiplying every score for a fixed query by the same positive constant leaves all comparison probabilities unchanged. The linear and exponential score links discussed in [zhao2025limits, Section 3.2] therefore impose different assumptions on the relation between rewards and comparisons.
Definition. Exponential-score Bradley--Terry feedback [ftip-009E]AGENTDRAFTED
Definition. Exponential-score Bradley--Terry feedback [ftip-009E]AGENTDRAFTED
The exponential-score link sets
\[ a_{\xi ,c}=\exp \left (u(\xi ,c(\xi ))\right ). \]For this link, exact comparison probabilities reveal pairwise utility differences through
\[ \log \frac {\Pr (c_i\succ _{\xi }c_j)} {\Pr (c_j\succ _{\xi }c_i)} =u(\xi ,c_i(\xi ))-u(\xi ,c_j(\xi )). \]This algebra explains why a known link and infinite noiseless frequency information can expose more than an ordinal order. It does not apply when the link is unknown or misspecified.
Definition. Linear-score Bradley--Terry feedback [ftip-009F]AGENTDRAFTED
Definition. Linear-score Bradley--Terry feedback [ftip-009F]AGENTDRAFTED
The linear-score link sets
\[ a_{\xi ,c}=u(\xi ,c(\xi )), \qquad \Pr (c_i\succ _{\xi }c_j) =\frac {u(\xi ,c_i(\xi ))} {u(\xi ,c_i(\xi ))+u(\xi ,c_j(\xi ))}. \]Write \(p^u_{\xi ,ij}\) for the displayed probability and define the complete pairwise-probability profile
\[ P_u^{\rm lin} =\left (p^u_{\xi ,ij}\right )_{\xi \in Q,\,c_i\neq c_j\in C_0}. \]This requires nonnegative utilities and a positive denominator for each queried pair. A linear-score algorithm \(\mathcal A_{\rm lin}\) takes \((\mathfrak m_0,P_u^{\rm lin})\) as input and returns \(\mathfrak m_{\mathcal A_{\rm lin}}(u)\). The following lower bound concerns this specific link; it is not a lower bound for every stochastic preference model.
Theorem. General linear-score noisy preference lower bound [ftip-009G]AGENTDRAFTED
Theorem. General linear-score noisy preference lower bound [ftip-009G]AGENTDRAFTED
Assume pointwise response separation as defined in Theorem [ftip-009A]. For every pretrained routing model and linear-score algorithm \(\mathcal A_{\rm lin}\), there exists a utility
\[ u:Q\times Y\longrightarrow [0,1]. \]Post-training from even the complete comparison-probability profile of the linear-score link then satisfies
\[ \operatorname {Dist}_u(\mathcal A_{\rm lin};\mathfrak m_0) \geq \widetilde \Omega \left ( \min \left \{|C_0|,R_{Q,\mathfrak E,H}\right \} \right ), \]where \(R_{Q,\mathfrak E,H}\) is defined in Theorem [ftip-009A]. The theorem is again existential in \(u\) and uses the source's deterministic comparator. The same circuitwise-utility issue recorded in Theorem [ftip-009A] prevents us from asserting the source's unrestricted pretrained-model quantifier here. Its noise is informative because probabilities depend on cardinal scores; the obstruction survives under the particular linear link.
This lower bound is the form of Appendix Theorem A.5 in The limits of preference data for post-training[zhao2025limits] with the additional pointwise response-separation assumption stated above.
Remark. The noisy main theorem and appendix have different asymptotic notation [ftip-009H]AGENTDRAFTED
Remark. The noisy main theorem and appendix have different asymptotic notation [ftip-009H]AGENTDRAFTED
The main-text Theorem 3.4 of The limits of preference data for post-training[zhao2025limits] displays \(\Omega (|C_0|)\) in its stated large-query regime. Appendix Theorem A.5 displays the general bound with \(\widetilde \Omega \) and the minimum in Theorem [ftip-009G]. The tilde can hide logarithmic factors, so these statements are not textually identical.
The general bound in Theorem [ftip-009G] has the appendix's rate with a possible logarithmic loss. Eliminating that loss to obtain the main-text rate requires an additional argument.
Definition. Cardinal value query [ftip-009I]AGENTDRAFTED
Definition. Cardinal value query [ftip-009I]AGENTDRAFTED
In the social-choice source, agents rank alternatives and also have nonnegative cardinal values. A value query takes an agent \(i\) and an alternative \(j\) and returns \(v_{ij}\) [amanatidis2021peeking, Definition 1].
Under the routing analogy, a query \(\xi \in Q\) plays the role of an agent and a circuit \(c\in C_0\) plays the role of an alternative. A cardinal query therefore reveals one value \(u(\xi ,c(\xi ))\). Query counts inherited from the social-choice theorem are per query/agent, not totals across \(Q\).
Theorem. Acceptable Range Voting information--distortion tradeoff [ftip-009J]AGENTDRAFTED
Theorem. Acceptable Range Voting information--distortion tradeoff [ftip-009J]AGENTDRAFTED
Let \(m\) be the number of alternatives and let \(k\in \{1,\ldots ,m\}\). Theorem 4 of Peeking behind the ordinal curtain: Improving distortion via cardinal queries[amanatidis2021peeking] states that \(k\)-Acceptable Range Voting uses
\[ O(k\log m) \]value queries per agent and has distortion
\[ O\left (m^{1/(k+1)}\right ). \]This is a social-choice mechanism theorem. It transfers directly to the singleton-representation specialization \(|H|=1\), where every query must use one common circuit. Under that restriction, queries are agents and circuits are alternatives as in Definition [ftip-009I]. The theorem does not by itself cover a routing comparator that may choose different circuits for different representations, and it is not an implementation of neural post-training.
This statement is Theorem 4 of Peeking behind the ordinal curtain: Improving distortion via cardinal queries[amanatidis2021peeking].
Corollary. Constant distortion with logarithmically many value queries per query [ftip-009K]AGENTDRAFTED
Corollary. Constant distortion with logarithmically many value queries per query [ftip-009K]AGENTDRAFTED
Taking \(k\) proportional to \(\log m\) in Theorem [ftip-009J] yields constant distortion with
\[ O(\log ^2 m) \]value queries per agent. This is Corollary 2 of Peeking behind the ordinal curtain: Improving distortion via cardinal queries[amanatidis2021peeking], inherited as Theorem 3.5 by The limits of preference data for post-training[zhao2025limits]. Under the routing analogy, the count is per query, so a full table over \(|Q|\) queries can require \(O(|Q|\log ^2m)\) values. The statement is an upper bound for the named mechanism in the common-circuit specialization of Theorem [ftip-009J]. It is not a result for the full routing comparator, nor a lower bound saying that this many values are necessary.
Remark. Information and optimization assumptions in the two finite models [ftip-009L]AGENTDRAFTED
Remark. Information and optimization assumptions in the two finite models [ftip-009L]AGENTDRAFTED
The two source families assume different information models; the diagram compares them without imposing an information order.
The KL identities characterize the exact optimizer for a declared scalar reward. The preference lower bounds are worst-case statements inside a fixed- circuit routing model. Bradley--Terry conclusions depend on the chosen score link. In the common-circuit specialization, cardinal queries change the information modality and admit a positive mechanism result. Outside that specialization, the preference and cardinal-query results are not directly comparable without further assumptions.
None of these statements derives the finite transcript theorem Theorem [ftip-007S], and none proves that benchmark gain is capability acquisition. Applying either result to a training system requires that system to satisfy the corresponding information, optimizer, and comparator assumptions.
Controlled coverage, feedback resolution, and prompt breadth [ftip-009M]AGENTDRAFTED
Controlled coverage, feedback resolution, and prompt breadth [ftip-009M]AGENTDRAFTED
This section studies finite measurements and controlled comparisons that separate starting-policy coverage from the information supplied by a reward. It also records how a training prompt law limits the scope of an observed post-training effect.
The empirical route is a controlled language-model post-training study. Its reported outcomes remain experiment-specific observations. Theorems in this section follow from the stated finite-probability assumptions; the empirical results alone do not imply those conclusions.
Starting-policy interventions [ftip-009N]AGENTDRAFTED
Starting-policy interventions [ftip-009N]AGENTDRAFTED
A comparison among starting policies is meaningful only after the task, training grid, feedback rule, and evaluation procedure have been declared. Observed differences are conditional on those experimental coordinates.
Remark. The source experiment as an intervention matrix [ftip-009O]AGENTDRAFTED
Remark. The source experiment as an intervention matrix [ftip-009O]AGENTDRAFTED
[clay2026demystifying, Sections 4.1--4.3 and Figure 1] organize the reported experiments along three declared axes: a starting model distribution, a training-prompt distribution, and a reward function. Each reported measurement therefore belongs to a cell of a matrix rather than to an unqualified ``RL post-training'' condition. The source holds its broad training recipe fixed while varying selected axes; it does not study variation among RL algorithms.
Each experimental comparison is conditional on its model, task, prompt law, executable reward rule, training budget, and evaluation procedure. The reward rule is especially consequential here because the main text and Appendix C do not state identical sparse-reward semantics. Section 4.2 describes target containment with a length penalty. Appendix C's prose says an exact target receives unit reward, but its displayed equation requires the response to be strictly longer than the target for any positive reward. These two descriptions do not identify a single sparse-reward implementation.
Definition. Target-response event [ftip-009P]AGENTDRAFTED
Definition. Target-response event [ftip-009P]AGENTDRAFTED
Fix an evaluation instance \(x\), a response space \(\mathcal Y_x\), and a declared target predicate \(h_x^\star :\mathcal Y_x\to \{0,1\}\). For a sampled response \(Y\), the target-response event is
\[ E_x^\star =\{h_x^\star (Y)=1\}. \]The predicate is part of the evaluation specification. It may test exact string equality after a declared normalization, containment of a target substring, equality of a parsed answer, or another explicitly typed condition. These predicates are not interchangeable. The movie-quote and AIME experiments in [clay2026demystifying, Sections 4.1--4.2] use different response objects and therefore require different target predicates.
Remark. Exact-string success and task utility are different predicates [ftip-009Q]AGENTDRAFTED
Remark. Exact-string success and task utility are different predicates [ftip-009Q]AGENTDRAFTED
Let \(y_x^\star \) be a designated string and let \(N_x\) be a declared normalizer. Exact-string success is the specialization \(h_x^\star (y)=\mathbf 1\{N_x(y)=N_x(y_x^\star )\}\) of Definition [ftip-009P]. A task utility may instead accept semantically equivalent answers, assign partial credit, invoke a verifier, or depend on evaluator randomness as in Convention [ftip-005D].
Consequently, a change in target-string match rate is not automatically a change in task utility. [clay2026demystifying, Sections 4.1--4.2] deliberately use narrow target behaviours to study controlled coverage. Transferring their measurements to broader capability requires a separately justified evaluator.
Definition. Base, SFT-positive, and SFT-negative starting-policy triple [ftip-009R]AGENTDRAFTED
Definition. Base, SFT-positive, and SFT-negative starting-policy triple [ftip-009R]AGENTDRAFTED
For one declared model family and target predicate, a starting-policy triple is
\[ \left (\pi ^{\mathrm {base}},\pi ^+,\pi ^-\right ). \]Here \(\pi ^{\mathrm {base}}\) is the unmodified starting policy, \(\pi ^+\) is obtained by a declared supervised update intended to increase target-response frequency, and \(\pi ^-\) is obtained by a declared update intended to decrease it. The superscripts name producing interventions, not mathematical order relations between the resulting policies.
[clay2026demystifying, Section 4.1] instantiates the triple with the source's Base, SFT-positive, and SFT-negative checkpoints. For the movie quote, its SFT mixture places twenty percent weight on the target quote and eighty percent on other quotes from the Cornell Movie-Dialogs corpus; the negative intervention maximizes cross-entropy loss on the target.
Remark. SFT-positive and SFT-negative are composite weight interventions [ftip-009S]AGENTDRAFTED
Remark. SFT-positive and SFT-negative are composite weight interventions [ftip-009S]AGENTDRAFTED
The policies \(\pi ^+\) and \(\pi ^-\) of Definition [ftip-009R] are produced by optimization. Their weights, output probabilities, representations, and off-target behaviours can all change together. Calling one intervention ``positive'' and the other ``negative'' describes its intended effect on the declared target response; it does not assert that only one probability mass was edited.
The comparisons in [clay2026demystifying, Sections 4.1 and 5.1] therefore test dependence on three constructed starting checkpoints. They do not identify a causal effect of initial target probability alone without an additional intervention model.
Definition. Controlled post-training experiment cell [ftip-009T]AGENTDRAFTED
Definition. Controlled post-training experiment cell [ftip-009T]AGENTDRAFTED
A controlled post-training experiment cell is a record
\[ \mathfrak c= (M,\pi ^{\mathrm {init}},\mathsf T,\mathcal D_{\mathrm {tr}}, r^{\mathrm {id}},\mathcal A,b_{\mathrm {tr}},\mathsf E), \]where \(M\) identifies the model architecture and checkpoint lineage, \(\pi ^{\mathrm {init}}\) is its starting policy, \(\mathsf T\) is the task, \(\mathcal D_{\mathrm {tr}}\) is the training-prompt law, \(r^{\mathrm {id}}\) identifies an executable reward rule and version, \(\mathcal A\) is the update procedure, \(b_{\mathrm {tr}}\) is the training budget, and \(\mathsf E\) is the evaluation interface. Random seeds and hyperparameters belong to the relevant record fields even when suppressed from the notation.
[clay2026demystifying, Figure 1 and Sections 4.1--4.3] motivates the coordinates. The source varies starting distribution, prompt distribution, and reward while using a common broad RL setup. Because its main-text and Appendix-C sparse rewards differ, the reward field is an identifier for an executable rule, not merely the word ``sparse.''
Definition. Matched cells and held-fixed coordinates [ftip-009U]AGENTDRAFTED
Definition. Matched cells and held-fixed coordinates [ftip-009U]AGENTDRAFTED
Let \(J\) index the coordinates of an experiment cell \(\mathfrak c\) from Definition [ftip-009T]. For \(S\subseteq J\), two cells \(\mathfrak c\) and \(\mathfrak c'\) are matched outside \(S\) when
\[ \mathfrak c_j=\mathfrak c'_j\qquad \text {for every }j\in J\setminus S. \]The coordinates in \(J\setminus S\) are the held-fixed coordinates; those in \(S\) are the declared intervention coordinates. Equality means equality at the resolution recorded by the experiment, including evaluation sample size when that size affects the reported statistic.
A matched comparison licenses a contrast between the recorded cells. It does not show that a named coordinate is internally atomic. In particular, matching outside the starting-policy coordinate leaves the composite-checkpoint qualification of Remark [ftip-009S] in force.
Example. Three starting laws under one declared training grid [ftip-009V]AGENTDRAFTED
Example. Three starting laws under one declared training grid [ftip-009V]AGENTDRAFTED
A source comparison may place the three starting policies of Definition [ftip-009R] into cells matched outside the starting-policy coordinate. The shared boxes below mean equality of the declared grid fields, not that the three checkpoints differ in only one scalar probability.
This is the comparison pattern used in [clay2026demystifying, Sections 4.1 and 5.1]. An actual cell still needs its model, task, reward implementation, and numerical record; the diagram is not a claim that all experiments in the paper instantiate one identical grid.
Remark. What the starting-policy comparison can and cannot identify [ftip-009W]AGENTDRAFTED
Remark. What the starting-policy comparison can and cannot identify [ftip-009W]AGENTDRAFTED
Within a declared model, task, training grid, and evaluation procedure, the three-cell comparison can establish that the measured post-training outcome differs across the source's constructed starting checkpoints. The movie-quote and AIME entries in [clay2026demystifying, Section 5.1, Tables 1--2] are empirical records of that form.
The comparison does not isolate initial target probability from every other SFT-induced weight change, prove that an observed zero has zero support, or establish acquisition of a broader capability. The reported model sets differ across the paper: [clay2026demystifying, Section 4.1] names OLMo 3, Qwen2-7B, Qwen3-1.7B, and Qwen2.5-7B-Instruct, while Table 1 and Appendix G also report Qwen3-8B and Qwen2-1.5B. Each measurement is specific to the model and configuration in its table row.
Finite initial-coverage measurement [ftip-009X]AGENTDRAFTED
Finite initial-coverage measurement [ftip-009X]AGENTDRAFTED
A finite evaluation records hits, not mathematical support. This subsection introduces the hit count and its sampling law, derives the exact zero-hit bound under independent sampling, and then returns to the limits of the source measurement.
Definition. Initial evaluation hit count [ftip-009Y]AGENTDRAFTED
Definition. Initial evaluation hit count [ftip-009Y]AGENTDRAFTED
Fix a starting policy, an evaluation sampling law, and the target predicate of Definition [ftip-009P]. Before post-training, draw evaluation records \((X_j,Y_j)_{j=1}^m\). Define the hit indicators and the initial evaluation hit count by
\[ I_j^\star =h_{X_j}^\star (Y_j), \qquad K_m=\sum _{j=1}^{m}I_j^\star . \]The sampling law determines whether the instances \(X_j\) are fixed, resampled, or stratified. The adjective ``initial'' locates the measurement before the post-training intervention; it does not assert that the samples are independent or that the starting policy is a foundation checkpoint.
Definition. Empirical initial success rate [ftip-009Z]AGENTDRAFTED
Definition. Empirical initial success rate [ftip-009Z]AGENTDRAFTED
For a nonempty initial evaluation sample of size \(m\), the empirical initial success rate is
\[ \widehat p_m=\frac {K_m}{m} =\widehat {\mathbb E}_{j\in \{1,\ldots ,m\}}[I_j^\star ], \]using the empirical-average convention of Convention [ftip-006Z]. This is a statistic of the declared sample. It is not, without a sampling model and an uncertainty statement, the exact successful-support probability \(p_P(x)\) of Definition [ftip-005U].
Remark. Zero observed hits are not zero probability [ftip-00A0]AGENTDRAFTED
Remark. Zero observed hits are not zero probability [ftip-00A0]AGENTDRAFTED
The equality \(K_m=0\) says that no target response occurred in one finite sample. Every success probability \(0\leq p<1\) assigns positive probability \((1-p)^m\) to this observation under independent Bernoulli sampling. Thus \(\widehat p_m=0\) does not imply \(p=0\), absence from mathematical support, or impossibility of discovery under a larger budget.
The entries printed as 0.00 percent in [clay2026demystifying, Section 5.1, Tables 1--2] are empirical rates at the stated evaluation sizes. They must not be rewritten as exact support claims.
Theorem. Zero-hit likelihood under iid evaluation [ftip-00A1]AGENTDRAFTED
Theorem. Zero-hit likelihood under iid evaluation [ftip-00A1]AGENTDRAFTED
Let \(m\in \mathbb N_{\geq 1}\). Assume the hit indicators from Definition [ftip-009Y] are independent Bernoulli variables with a common success probability \(p\). Then \(K_m\) has the binomial law and
\[ \Pr _p(K_m=0)=(1-p)^m. \]
Proof.
Proof.
The event \(K_m=0\) is \(\bigcap _{j=1}^m\{I_j^\star =0\}\). Independence and \(\Pr _p(I_j^\star =0)=1-p\) give the displayed product.
This finite statement follows from the displayed hypotheses. Applying it to a source table requires the additional iid and stationary-success assumptions stated above.
Corollary. Exact one-sided bound after zero hits [ftip-00A2]AGENTDRAFTED
Corollary. Exact one-sided bound after zero hits [ftip-00A2]AGENTDRAFTED
Assume Theorem [ftip-00A1] with \(m\in \mathbb N_{\geq 1}\) and fix \(0<\delta <1\). If \(K_m=0\), inversion of the exact zero-count likelihood gives the one-sided upper endpoint
\[ u_{m,\delta }=1-\delta ^{1/m}. \]Indeed, \(\Pr _{u_{m,\delta }}(K_m=0)=\delta \), and for every \(p>u_{m,\delta }\) one has \(\Pr _p(K_m=0)<\delta \). Thus the observed zero count excludes probabilities above \(u_{m,\delta }\) at exact level \(\delta \) under the declared iid model.
Proof.
Proof.
By Theorem [ftip-00A1], the zero-count likelihood is \((1-p)^m\), which is strictly decreasing in \(p\). Solving \((1-p)^m=\delta \) gives the endpoint and the stated strict inequality.
This is a likelihood inversion derived from the displayed finite setup, not a source theorem and not a support certificate.
Example. The 128-sample zero-hit bound [ftip-00A3]AGENTDRAFTED
Example. The 128-sample zero-hit bound [ftip-00A3]AGENTDRAFTED
Take \(m=128\) and \(\delta =0.05\) in Corollary [ftip-00A2]. After zero hits, the exact one-sided upper endpoint is
\[ u_{128,0.05} =1-0.05^{1/128} \approx 0.02313. \]Under the iid Bernoulli model, probabilities above approximately 2.313 percent make a zero count less than five percent likely. The calculation does not turn a recorded \(0/128\) into proof that the true probability is zero, and it does not apply if the 128 evaluations have a different joint sampling law.
Definition. First positive sparse-reward time [ftip-00A4]AGENTDRAFTED
Definition. First positive sparse-reward time [ftip-00A4]AGENTDRAFTED
Fix an executable sparse-reward rule and let \(r_j^{\mathrm {sp}}\) be the reward returned on rollout \(j\). The first positive sparse-reward time is the extended-valued index
\[ J_+=\inf \{j\geq 1:r_j^{\mathrm {sp}}>0\}, \qquad \inf \varnothing :=\infty . \]This definition concerns the reward implementation named by an experiment cell. The event \(r_j^{\mathrm {sp}}>0\) coincides with a target-response event only when that equality is part of the declared reward semantics. In particular, a length penalty or partial-credit rule can separate positive reward from exact target match.
Corollary. Sparse-reward discovery within a rollout budget [ftip-00A5]AGENTDRAFTED
Corollary. Sparse-reward discovery within a rollout budget [ftip-00A5]AGENTDRAFTED
Suppose the events \(\{r_j^{\mathrm {sp}}>0\}\) are independent and have a common probability \(q\). For every positive rollout budget \(B\),
\[ \Pr (J_+\leq B)=1-(1-q)^B. \]
Proof.
Proof.
Apply the independent-attempt theorem Theorem [ftip-0078] with \(E_j=\{r_j^{\mathrm {sp}}>0\}\). Its discovery event is exactly \(\{J_+\leq B\}\).
This is a specialization proved from the displayed hypotheses. It does not supply independence, stationarity, or the value of \(q\) for a training run, and it does not equate positive proxy reward with task utility.
Example. The AIME 128-sample measurement record [ftip-00A6]AGENTDRAFTED
Example. The AIME 128-sample measurement record [ftip-00A6]AGENTDRAFTED
[clay2026demystifying, Section 5.1, Table 2] reports the following empirical target-answer rates for AIME Problem 4 with Qwen2.5-7B-Instruct and evaluation size \(m=128\). The task asks for the number of integer pairs \((x,y)\in [-100,100]^2\) satisfying \(12x^2-xy-6y^2=0\); the target answer is \(117\).
\[ \begin {array}{c|ccc} &\mathrm {SFT{+}}&\mathrm {Base}&\mathrm {SFT{-}}\\ \hline \text {No Reward}&26.6&3.92&0.00\\ \text {Sparse Reward}&85.9&10.2&0.00\\ \text {Dense Reward}&86.7&92.2&0.00 \end {array} \]Every entry in the displayed array is a percentage.
These are source-reported empirical percentages, not exact policy probabilities. ``No Reward'' is retained as the source's row label; the table alone does not define it as a post-training protocol. The three zero entries for SFT-negative are finite observations and remain subject to Remark [ftip-00A0]. Appendix Figure 5's caption prints a different set of Qwen2.5-7B-Instruct values that duplicates the neighbouring movie-quote caption and is incompatible with Table 2. The displayed percentages are those of Table 2; the caption does not provide a consistent alternative measurement.
Remark. An observed plateau is not a universal probability threshold [ftip-00A7]AGENTDRAFTED
Remark. An observed plateau is not a universal probability threshold [ftip-00A7]AGENTDRAFTED
[clay2026demystifying, Section 5.2 and Figure 2] report that the Qwen3-1.7B Base movie-quote cell, whose initial empirical match rate is about 0.5 percent, does not optimize under the source's sparse-reward run, whereas its dense-reward run rises toward fifty percent. [clay2026demystifying, Appendix Figure 8] gives final match rates 10.0 percent for sparse reward and 48.8 percent for dense reward. Thus ``failed'' here means failure of the reported sparse run to optimize as intended, not zero final matches.
A plateau is indexed by the model, target, reward implementation, optimizer, sampling process, and budget in its experiment cell. One observed transition therefore does not identify a universal initial-probability threshold for RL learning, support, or capability acquisition.
Sparse, dense, and process feedback [ftip-00A8]AGENTDRAFTED
Sparse, dense, and process feedback [ftip-00A8]AGENTDRAFTED
Sparse, dense, and process rewards expose different observations about a response. This subsection treats that difference as a change in the feedback channel, rather than as a free change in the smoothness of one fixed objective.
Definition. Sparse exact reward [ftip-00A9]AGENTDRAFTED
Definition. Sparse exact reward [ftip-00A9]AGENTDRAFTED
Let \(\mathcal Y\) be a finite response set and fix a target response \(\tau \in \mathcal Y\). The sparse exact reward is the map \(r_{\rm exact}:\mathcal Y\to \{0,1\}\) defined by
\[ r_{\rm exact}(y)=\mathbf 1\{y=\tau \}. \]This idealized reward exposes one bit: whether the whole response equals the target. It does not expose a prefix, edit location, or partial milestone. The movie-quote source uses related but textually inconsistent substring and length-penalized rewards; the distinct formulas are compared in Remark [ftip-00AA].
Remark. Main-text and Appendix-C sparse-reward discrepancy [ftip-00AA]AGENTDRAFTED
Remark. Main-text and Appendix-C sparse-reward discrepancy [ftip-00AA]AGENTDRAFTED
Section 4.2 of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] displays a substring indicator \(\mathbf 1\{\tau \subseteq y\}\) and says that a length penalty is applied. In Appendix C, \(n\) is the maximum generation length and \(s\) is the number of tokens beyond the target. The appendix first defines the excess-length penalty
\[ p(s)= \begin {cases} 0,&s=0,\\ s/n,&s>0, \end {cases} \]and then gives Equation (3):
\[ r_{\rm C}(y,\tau )= \begin {cases} \max \{0.5,1-p(s)\},&\tau \text { occurs in }y \text { and }|y|>|\tau |,\\ 0,&\text {otherwise}. \end {cases} \]As printed, Equation (3) assigns zero when \(y=\tau \), because its first branch requires strict excess length. This conflicts with the immediately preceding Appendix-C prose, which assigns base reward one when the target is generated, and it is not the exact-match reward of Definition [ftip-00A9]. The two printed descriptions therefore specify different reward rules.
Definition. Edit-distance reward [ftip-00AB]AGENTDRAFTED
Definition. Edit-distance reward [ftip-00AB]AGENTDRAFTED
Let \(y=y_1\cdots y_m\) and a nonempty target \(\tau =\tau _1\cdots \tau _n\) be finite strings. Their Levenshtein distance is determined by \(D(0,j)=j\), \(D(i,0)=i\), and, for \(i,j>0\),
\[ D(i,j)=\min \left \{ \begin {aligned} &D(i-1,j)+1,\\ &D(i,j-1)+1,\\ &D(i-1,j-1)+\mathbf 1\{y_i\neq \tau _j\} \end {aligned} \right \}. \]Set \(L(y,\tau )=\max \{|y|,|\tau |\}\). The edit-distance reward is
\[ r_{\rm edit}(y,\tau ) =\max \left \{0,1-\frac {D(|y|,|\tau |)}{L(y,\tau )}\right \}. \]The recurrence is Equation (1) in the main text and Equation (4) in Appendix C of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying]; the normalized reward is its Equation (5). The nonempty-target assumption makes the displayed denominator positive. This reward does not establish that edit similarity is the correct utility for a different task.
Remark. Dense reward imports target structure [ftip-00AC]AGENTDRAFTED
Remark. Dense reward imports target structure [ftip-00AC]AGENTDRAFTED
The edit reward of Definition [ftip-00AB] is not obtained from the binary value in Definition [ftip-00A9] by a numerical smoothing operation. It also receives the target string, a character-level edit model, and the ordering of symbols. Two non-target responses that both receive sparse reward zero can therefore receive different edit rewards.
That extra resolution can improve credit assignment, but it changes the feedback channel and its assumptions. The source calls edit distance a dense proxy and reports controlled movie-quote experiments [clay2026demystifying, Sections 4.2 and 5.2]. Neither the formula nor those observations establish that edit proximity is an independent measure of general response quality.
Definition. Milestone process reward [ftip-00AD]AGENTDRAFTED
Definition. Milestone process reward [ftip-00AD]AGENTDRAFTED
For the source's fixed AIME problem, let
\[ M(y)=(m_1(y),\ldots ,m_5(y))\in \{0,1\}^5 \]record whether a completed response contains five declared milestones: a valid algebraic setup, correct root relations, correct integer bounds, a correct count for at least one branch, and correct subtraction of the overlap at the origin. With
\[ (w_1,\ldots ,w_5)=(0.05,0.05,0.10,0.15,0.25), \]the milestone process reward is
\[ r_{\rm proc}(y)=\sum _{i=1}^{5}w_i m_i(y). \]Appendix D.1 of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] gives Equation (6) and the milestone list above. In the experiment, a 32-billion-parameter instruction-tuned model classifies the completed trajectory. The displayed map is therefore richer than a deterministic final-answer verifier, even though it returns one scalar after the rollout.
Remark. Process feedback assumptions and milestone-weight discrepancy [ftip-00AE]AGENTDRAFTED
Remark. Process feedback assumptions and milestone-weight discrepancy [ftip-00AE]AGENTDRAFTED
Appendix D.2 of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] supplements \(r_{\rm proc}\) with an extracted-answer override and two penalties. Translating its notation, let \(\tau =117\), \(\tau _{\rm near}=118\), and define
\[ r_{\rm base}(y)= \begin {cases} 1.0,&\operatorname {extract}(y)=\tau ,\\ 0.6,&\operatorname {extract}(y)=\tau _{\rm near},\\ r_{\rm proc}(y),&\text {otherwise}. \end {cases} \]Let \(p_{\rm loop}(y)=-0.3\) when the judge flags a loop without the exact answer, and zero otherwise. Let \(p_{\rm format}(y)=-0.5\) when the response lacks the required boxed delimiter, and zero otherwise. Equations (7)--(8) then give
\[ r_{\rm PRM}(y) =\max \{0,r_{\rm base}(y)+p_{\rm loop}(y)+p_{\rm format}(y)\}. \]These clauses assume a reliable milestone judge, parser, near-miss choice, loop flag, and formatting rule. They are part of the feedback definition, not consequences of reinforcement learning. The main text describes ``exponentially increasing'' dense rewards, and Appendix D calls the weights ``exponential scaling.'' The printed vector \((0.05,0.05,0.10,0.15,0.25)\) is neither strictly increasing at every milestone nor a geometric progression. We preserve the exact weights and do not infer an exponential law from that wording.
Definition. Reward-induced observational equivalence [ftip-00AF]AGENTDRAFTED
Definition. Reward-induced observational equivalence [ftip-00AF]AGENTDRAFTED
Let \(\mathcal Y\) be a finite response set and \(r:\mathcal Y\to \mathcal R\) any reward map. Two responses are observationally equivalent under \(r\), written \(y\sim _r y'\), when
\[ y\sim _r y'\quad \Longleftrightarrow \quad r(y)=r(y'). \]Equality makes \(\sim _r\) an equivalence relation. Its quotient \(\mathcal Y/{\sim _r}\) is the finite set of response classes distinguished by the reward alone. This proposed equivalence relation ignores any information in the response that is not returned by \(r\); equal rewards need not imply equal latent utility.
Lemma. Refining feedback separates at least as many responses [ftip-00AG]AGENTDRAFTED
Lemma. Refining feedback separates at least as many responses [ftip-00AG]AGENTDRAFTED
Let \(\mathcal Y\) be finite and let \(r_1:\mathcal Y\to \mathcal R_1\) and \(r_2:\mathcal Y\to \mathcal R_2\). Say that \(r_2\) refines \(r_1\) when
\[ r_2(y)=r_2(y')\quad \Longrightarrow \quad r_1(y)=r_1(y') \qquad (y,y'\in \mathcal Y). \]If \(r_2\) refines \(r_1\), then
\[ \left |\mathcal Y/{\sim _{r_2}}\right | \geq \left |\mathcal Y/{\sim _{r_1}}\right |. \]
Proof.
Proof.
Send the \(r_2\)-class of \(y\) to the \(r_1\)-class of \(y\). The refinement condition makes this map well defined. It is surjective because every \(r_1\)-class contains some \(y\), whose \(r_2\)-class maps to it. A surjection between finite sets has a domain at least as large as its codomain.
This finite lemma compares observational partitions only. It does not say that the refined reward is cheaper, more accurate, or better aligned with utility.
Example. Counterexample: equal sparse reward, unequal dense reward [ftip-00AH]AGENTDRAFTED
Example. Counterexample: equal sparse reward, unequal dense reward [ftip-00AH]AGENTDRAFTED
Take the target string \(\tau =\texttt {abc}\) and two responses \(y=\texttt {abx}\) and \(y'=\texttt {xyz}\). Both fail exact matching, while their edit distances and normalized edit rewards are
\[ \begin {array}{c|c|c|c} \text {response}&r_{\rm exact}&D(\,cdot\,,\tau )&r_{\rm edit}\\ \hline \texttt {abx}&0&1&2/3\\ \texttt {xyz}&0&3&0 \end {array} \]Thus \(y\sim _{r_{\rm exact}}y'\) but \(y\not \sim _{r_{\rm edit}}y'\). The example witnesses a strict separation inside one sparse-reward class. It does not claim that every dense proxy refines every sparse verifier.
Example. Three feedback resolutions on one response set [ftip-00AI]AGENTDRAFTED
Example. Three feedback resolutions on one response set [ftip-00AI]AGENTDRAFTED
One finite response set can be observed through three different maps. The arrows below share a domain; they do not assert that the three codomains form a refinement chain.
The exact reward forgets every difference among failures. Edit reward can retain character-level proximity, while the source process reward retains a declared milestone vector only after judge, override, and penalty choices. The partition lemma Lemma [ftip-00AG] applies to a pair only after its refinement hypothesis has been checked.
Remark. Reward density is not cost-free smoothing [ftip-00AJ]AGENTDRAFTED
Remark. Reward density is not cost-free smoothing [ftip-00AJ]AGENTDRAFTED
A denser reward can distinguish more responses and supply more frequent update signal. It can also require information absent from a sparse verifier. In the controlled source, edit feedback assumes the full target and computes a string metric; process feedback uses a 32-billion-parameter judge, five problem-specific milestones, answer extraction, an enumerated near miss, and loop and format penalties [clay2026demystifying, Appendices C--D].
The richer feedback channel incurs specification, computation, and validation costs. Replacing sparse feedback by dense feedback can alter both the information available to training and the objective being optimized. The resulting comparison is an intervention on feedback resolution, not evidence that one fixed reward was smoothed at zero cost.
Prompt breadth and effect locality [ftip-00AK]AGENTDRAFTED
Prompt breadth and effect locality [ftip-00AK]AGENTDRAFTED
Training on one prompt law can change behavior unevenly across evaluation slices. Localized and distributed degradation are distinguished relative to that training law and the specified evaluation slices.
Definition. Training prompt law and evaluated prompt slice [ftip-00AL]AGENTDRAFTED
Definition. Training prompt law and evaluated prompt slice [ftip-00AL]AGENTDRAFTED
Let \(\mathcal X\) be a task-instance set. Write \(\mu _{\rm tr}=\mathcal D_{\rm tr}\) for the training-prompt coordinate of an experiment cell in Definition [ftip-009T]. A training prompt law is this probability law on \(\mathcal X\), used to draw instances during a post-training protocol. Let \(\mu _{\rm ev}\) be an independently declared evaluation law on the same set.
An evaluated prompt slice is a measurable set \(C\subseteq \mathcal X\) with \(\mu _{\rm ev}(C)>0\). Its conditional evaluation law is
\[ \mu _{\rm ev}(A\mid C) =\frac {\mu _{\rm ev}(A\cap C)}{\mu _{\rm ev}(C)}. \]The training and evaluation laws need not agree. A slice records where an effect is measured; it does not assert that prompts inside the slice are equally difficult or represented equally in pretraining. We specialize the task-law convention of Definition [ftip-001Q].
Definition. Source-specific narrow and broad configurations [ftip-00AM]AGENTDRAFTED
Definition. Source-specific narrow and broad configurations [ftip-00AM]AGENTDRAFTED
A prompt configuration is the record
\[ \mathsf c=(M_0,\mu _{\rm tr},m_{\rm tr},r,\mathsf A,b), \]containing the starting artifact, training prompt law, finite prompt-pool size, reward, update algorithm, and training budget. We call two particular records \(\mathsf c_{\rm nar}\) and \(\mathsf c_{\rm brd}\) only when a cited experiment names them narrow and broad.
Section 4.3 and Appendix F of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] instantiate these labels in two model-family experiments. The Qwen comparison uses 100 DeepScaleR prompts versus 10,000 WildChat prompts. The OLMo comparison uses 100 math-only prompts versus 10,000 prompts split evenly among mathematics, instruction following, and code. These labels identify the two reported configurations; they do not define a general measure or ordering of prompt breadth.
Remark. Prompt breadth is not a total order [ftip-00AN]AGENTDRAFTED
Remark. Prompt breadth is not a total order [ftip-00AN]AGENTDRAFTED
The records in Definition [ftip-00AM] change several coordinates together. The prompt-pool size, domain mixture, and repetition frequency differ. Across the paper's Qwen and OLMo studies, the starting artifact and evaluated tasks also differ.
We therefore use ``narrow'' and ``broad'' as names for the source cells. They do not define a total order on prompt laws, and their comparison does not identify a causal effect of breadth alone. A breadth theorem would need a declared statistic and matched configurations that differ only in that statistic.
Definition. Slice-conditioned success change [ftip-00AO]AGENTDRAFTED
Definition. Slice-conditioned success change [ftip-00AO]AGENTDRAFTED
Fix an evaluated slice \(C\) from Definition [ftip-00AL], and let \(P_0\) and \(P_1\) denote the pre- and post-training protocols whose successful-support probabilities are defined in Definition [ftip-005U]. The slice-conditioned success change is
\[ \Delta _{\rm suc}(C;P_1,P_0) =\mathbb E_{X\sim \mu _{\rm ev}(\cdot \mid C)} \left [p_{P_1}(X)-p_{P_0}(X)\right ]. \]The evaluation interface, inference budget, and success predicate are held fixed across the two terms. The quantity is an average change on one declared slice. It neither locates the change inside the model nor identifies which training coordinate caused it.
Definition. Localized and distributed degradation [ftip-00AP]AGENTDRAFTED
Definition. Localized and distributed degradation [ftip-00AP]AGENTDRAFTED
Fix pairwise disjoint evaluated slices \(C_1,\ldots ,C_J\) and a declared degradation threshold \(\kappa >0\). Define the set of materially degraded slices
\[ \mathcal H_\kappa (P_1,P_0) =\left \{j:\Delta _{\rm suc}(C_j;P_1,P_0)\leq -\kappa \right \}. \]Degradation is localized relative to this slice family and threshold when \(|\mathcal H_\kappa |=1\). It is distributed when \(|\mathcal H_\kappa |\geq 2\).
These terms depend on the chosen partition, threshold, and evaluation budget. They do not turn a finite benchmark vector into a statement about all capabilities.
Example. Narrow and broad random-reward paths [ftip-00AQ]AGENTDRAFTED
Example. Narrow and broad random-reward paths [ftip-00AQ]AGENTDRAFTED
Section 5.3 and Appendix F of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] supply two OLMo paths; Figure 4 reports their outcomes. Both replace the usual verifiable reward with a random scalar drawn from \(\operatorname {Unif}[0,1]\), but their prompt configurations differ.
In the narrow SFT-start path, GSM8K accuracy falls from 86 to about 32 by step 400, while the reported MMLU and IFEval changes are much smaller. In the broad path, the source reports an entropy spike near step 400 together with collapse on GSM8K, MMLU, and IFEval. The diagram records that interpretation; it does not isolate prompt breadth from pool size, mixture, or repetition.
Remark. What the source observes about spurious reward [ftip-00AR]AGENTDRAFTED
Remark. What the source observes about spurious reward [ftip-00AR]AGENTDRAFTED
Section 5.3 and Figures 3--4 of Demystifying Reinforcement Learning Post-Training of Language Models[clay2026demystifying] report that the Qwen narrow configuration retains higher MATH and AMC Acc@1 than its broad configuration under random reward. The OLMo experiment reports the different evaluation patterns summarized in Example [ftip-00AQ].
These are finite empirical observations. The random scalar reward removes task alignment from one feedback channel, but it does not hold all other training coordinates fixed. The reported entropy is a named token statistic, not a direct measure of capability or acquisition.
Example. Counterexample: equal marginal reward, unequal prompt-local damage [ftip-00AS]AGENTDRAFTED
Example. Counterexample: equal marginal reward, unequal prompt-local damage [ftip-00AS]AGENTDRAFTED
Let two evaluation slices \(C_1,C_2\) have equal mass. A feedback channel returns an independent Bernoulli reward with mean \(1/2\) under either of two post-training protocols. Suppose their fixed-interface success changes are
\[ \left (\Delta _{\rm suc}(C_1),\Delta _{\rm suc}(C_2)\right ) =(-1,0) \quad \hbox {or}\quad \left (-\tfrac 12,-\tfrac 12\right ). \]
The reward law and its mean are identical, but the slice-level evaluation vectors differ. Hence marginal training reward does not determine whether damage is localized or distributed. This is a finite counterexample, not a claim about the mechanism in the source experiment.
Remark. Coverage, feedback resolution, and prompt-conditioned effects [ftip-00AT]AGENTDRAFTED
Remark. Coverage, feedback resolution, and prompt-conditioned effects [ftip-00AT]AGENTDRAFTED
The source cells motivate tests of starting-policy coverage, feedback resolution, and prompt-conditioned damage. They do not establish that dense reward creates mathematical support, that zero sampled hits imply zero probability, or that random reward has one model-independent effect.
Separating the effects of coverage, feedback resolution, and prompt breadth requires stronger controls. One comparison fixes prompt laws and varies only the feedback sigma-algebra. Another fixes feedback and evaluation while varying one starting-policy coordinate. Confidence regions for the complete vector of slice-conditioned changes would quantify effects that an aggregate score can hide.
The reported observations remain conditional on their experimental configurations. They do not establish general results about capability acquisition, elicitation, or the optimal allocation of post-training compute.
Finite consequences and counterexamples [ftip-00JE]AGENTDRAFTED
Finite consequences and counterexamples [ftip-00JE]AGENTDRAFTED
Finite sampling, reward information, and deterministic execution give conditional conclusions about post-training. Their counterexamples show why the task law, feasible set, and available information cannot be omitted.
This synthesis brings together the finite results used in the evaluation analysis. The conceptual-discovery chapter asks whether such arguments can constrain a complete learning lineage, including changes to representations, curricula and research procedures.
Probability, information, and execution [ftip-00I1]AGENTDRAFTED
Probability, information, and execution [ftip-00I1]AGENTDRAFTED
Discovery probabilities, support, proxy error, feedback resolution, and replay each constrain a different part of a comparison. Capability remains conditional behavior under a declared intervention and evaluation law, rather than a scalar latent property.
Finite probability and execution results [ftip-00I2]AGENTDRAFTED
Finite probability and execution results [ftip-00I2]AGENTDRAFTED
The conclusions depend on their declared probability laws, finite index sets, positivity conditions, and execution inputs. Changing one of these assumptions can change the result even when the observed score is unchanged.
Convention. Domains of the finite results [ftip-00I5]AGENTDRAFTED
Convention. Domains of the finite results [ftip-00I5]AGENTDRAFTED
Each result concerns its declared carriers \(X_1,\ldots ,X_n\), with fixed equality and order conventions. Finiteness, probability laws, and positivity conditions are hypotheses of the result; they cannot be inferred from a finite observation alone.
Theorem. Independent discovery probability [ftip-00I7]AGENTDRAFTED
Theorem. Independent discovery probability [ftip-00I7]AGENTDRAFTED
For \(B\in \mathbb N\) independent discovery events with the probabilities declared in Convention [ftip-0077], the identity in Theorem [ftip-0078] gives \(\Pr (D_B)=1-\prod _{i=1}^{B}(1-p_i)\).
Theorem. Discovery budget for a failure threshold [ftip-00I8]AGENTDRAFTED
Theorem. Discovery budget for a failure threshold [ftip-00I8]AGENTDRAFTED
Under \(0<p<1\), \(0<\delta <1\), and an integer budget \(B\geq 1\), the failure constraint is equivalent to the following bound.
\[B\geq \left \lceil \frac {\log \delta }{\log (1-p)}\right \rceil .\]The result is proved in Corollary [ftip-0079].
Theorem. Support under finite exponential tilting [ftip-00I9]AGENTDRAFTED
Theorem. Support under finite exponential tilting [ftip-00I9]AGENTDRAFTED
Under the finite-carrier and positive-temperature hypotheses of Theorem [ftip-007C], normalized exponential tilting preserves the base law's positive support.
Theorem. Uniform proxy error and objective regret [ftip-00IA]AGENTDRAFTED
Theorem. Uniform proxy error and objective regret [ftip-00IA]AGENTDRAFTED
For a finite common feasible set and a common regularizer, the uniform proxy error hypothesis in Definition [ftip-007G] yields the two-epsilon objective regret bound proved in Theorem [ftip-007H]; the conclusion concerns the regularized objective named there.
Theorem. Utility under a change of evaluation law [ftip-00IB]AGENTDRAFTED
Theorem. Utility under a change of evaluation law [ftip-00IB]AGENTDRAFTED
If the evaluation laws and finite response space satisfy the total-variation hypotheses of Theorem [ftip-00GM], then the expectation difference is bounded by the stated sup-norm times total variation.
Theorem. Response classes under feedback refinement [ftip-00IC]AGENTDRAFTED
Theorem. Response classes under feedback refinement [ftip-00IC]AGENTDRAFTED
For finite response set \(\mathcal Y\) and deterministic rewards, a reward channel that refines the equality partition of another channel separates at least as many response classes, as proved in Lemma [ftip-00AG].
Theorem. Equal execution inputs give equal replay traces [ftip-00IJ]AGENTDRAFTED
Theorem. Equal execution inputs give equal replay traces [ftip-00IJ]AGENTDRAFTED
If the execution map is deterministic in all coordinates fixed by Definition [ftip-00HF], then equal input, revision, environment, and seed records produce equal finite traces, as proved in Theorem [ftip-00HG].
Theorem. Observational equivalence under a common update kernel [ftip-00IK]AGENTDRAFTED
Theorem. Observational equivalence under a common update kernel [ftip-00IK]AGENTDRAFTED
For the finite transcript and world kernels declared in Definition [ftip-008C]--Definition [ftip-008D], observationally equivalent worlds induce the same output law for any common randomized post-training kernel, as proved in Theorem [ftip-007S].
Theorem. Conditions for an admissible commit decision [ftip-00IL]AGENTDRAFTED
Theorem. Conditions for an admissible commit decision [ftip-00IL]AGENTDRAFTED
Under the typed audit record of Definition [ftip-00HL], a commit is admissible exactly when all required checks pass, the digest matches, and the recorded decision is \(commit\), as proved in Theorem [ftip-00HM].
Theorem. Admission of a finite audit plan [ftip-00IM]AGENTDRAFTED
Theorem. Admission of a finite audit plan [ftip-00IM]AGENTDRAFTED
A finite audit plan with nonnegative stage costs is admissible exactly when its declared additive cost is within budget; adding a positive stage beyond slack is inadmissible, by Theorem [ftip-00HX].
Counterexamples and restricted assumptions [ftip-00ID]AGENTDRAFTED
Counterexamples and restricted assumptions [ftip-00ID]AGENTDRAFTED
Finite constructions can separate average success from coverage, proxy accuracy from evaluation quality, and observed gradients from the hypotheses needed to bound them. Each separation identifies an assumption that a stronger conclusion would require.
Remark. What a finite counterexample establishes [ftip-00IE]AGENTDRAFTED
Remark. What a finite counterexample establishes [ftip-00IE]AGENTDRAFTED
A finite assignment satisfying a claim's hypotheses and violating its conclusion disproves that universal claim. It does not estimate how often the failure occurs under another distribution or establish a general failure rate.
Remark. Changing the model or evaluation changes the claim [ftip-00IF]AGENTDRAFTED
Remark. Changing the model or evaluation changes the claim [ftip-00IF]AGENTDRAFTED
A conclusion about fixed carriers, policies, feedback, budgets, and evaluation laws need not survive a change to those objects. Finite zero hits do not imply zero support, empirical benchmark movement does not imply acquisition, and an exact-optimizer result need not hold for an approximate optimizer without an additional error bound.
Example. Equal averages and zero hits do not identify coverage [ftip-00IG]AGENTDRAFTED
Example. Equal averages and zero hits do not identify coverage [ftip-00IG]AGENTDRAFTED
The two-task examples in Example [ftip-007E] and Example [ftip-00A3] show that equal one-shot averages or zero observed hits can coexist with different coverage or nonzero latent rates. These conclusions use their declared iid model and do not estimate rates outside it.
Example. Small training-law error can reverse evaluation selection [ftip-00IH]AGENTDRAFTED
Example. Small training-law error can reverse evaluation selection [ftip-00IH]AGENTDRAFTED
In the two-point construction of Example [ftip-007J], training-law average error is small while evaluation selection reverses. The missing hypothesis is a uniform bound on the evaluated feasible set; an informal promise of similar distributions does not supply it.
Remark. Untied heads, shared gradients, and checkpoint forecasts [ftip-00II]AGENTDRAFTED
Remark. Untied heads, shared gradients, and checkpoint forecasts [ftip-00II]AGENTDRAFTED
For DGG, the untied head identity and its finite-batch Jensen bound in Theorem [ftip-007Z] and Theorem [ftip-0081] differ from an intermediate-occurrence bound. A shared intermediate weight requires the sum over all occurrences in Theorem [ftip-007Z]; the source's local hypotheses do not establish its claimed total-gradient bound in [miao2026when, Section 4.2.1, Lemma 1, Theorem 1, and Appendix A.3]. The cancellation example Example [ftip-0084] also separates the active clipping interval from the raw-surrogate extension.
NExt's empirical checkpoint forecasts in [chen2026lowrank, Sections 3.2, 4.1--4.3, and 5.1] do not establish a universal subspace-collapse, capability, or speed theorem. The spectral and evaluation quantities in Definition [ftip-0086] through Remark [ftip-008B] measure different trajectory properties.
Mathematical notation [ftip-00IN]AGENTDRAFTED
Mathematical notation [ftip-00IN]AGENTDRAFTED
Prompt and response spaces, probability laws, policies, rewards, evaluation scores, and execution traces are distinct mathematical objects.
Convention. Prompt spaces, response spaces, and laws [ftip-00IO]AGENTDRAFTED
Convention. Prompt spaces, response spaces, and laws [ftip-00IO]AGENTDRAFTED
Use \(\mathcal X\) for prompts, \(\mathcal Y\) for finite responses, \(\Omega \) for sample space, \(\mathsf P\) for a declared protocol, and \(\mu \) for a prompt law. A probability law is written \(\Pr \) only after its sample space is named.
Convention. Policies and reference policies [ftip-00IP]AGENTDRAFTED
Convention. Policies and reference policies [ftip-00IP]AGENTDRAFTED
Use \(\pi \) for a policy, \(\pi _{\rm base}\) for a reference policy, and \(\pi _\theta \) for a parameterized policy. A policy is always typed as a kernel from the declared prompt carrier to the declared response carrier.
Convention. Rewards and evaluation utilities [ftip-00IQ]AGENTDRAFTED
Convention. Rewards and evaluation utilities [ftip-00IQ]AGENTDRAFTED
Use \(r:\mathcal X\times \mathcal Y\to \mathbb R\) for a deterministic reward and \(u\) for an evaluation utility. Proxy, verifier, and process rewards retain their local subscripts; no bare symbol silently changes meaning.
Convention. Model artifacts and evaluation scores [ftip-00IR]AGENTDRAFTED
Convention. Model artifacts and evaluation scores [ftip-00IR]AGENTDRAFTED
Use \(M\) for a model artifact, \(\mathsf E\) for an evaluation protocol, and \(J_{\mathsf E}(M)\) for its declared score. A comparison must state the invariant evaluation law before subtracting two scores.
Convention. Traces, states, lineages, and costs [ftip-00IS]AGENTDRAFTED
Convention. Traces, states, lineages, and costs [ftip-00IS]AGENTDRAFTED
Use \(z_{0:n}\) for a finite trace, \(s_t\) for a harness state, \(\ell \) for a lineage, and \(c\) for an execution cost. Event logs and summaries are distinct carriers even when one is computed from the other.
Architecture-conditioned potential and computation [ftip-00JC]AGENTDRAFTED
Architecture-conditioned potential and computation [ftip-00JC]AGENTDRAFTED
This chapter refines the evaluation framework for claims that depend on architecture, optimization geometry or a systems implementation. It begins with the decoder-only Transformer, then maps mechanism families to capability bottlenecks before introducing architecture-indexed frontiers and matched-compute comparisons. It also studies how an optimizer can depend on the representation of its parameters.
The reference architecture specifies how token probabilities are computed; it does not replace the shared task and evaluation interfaces. The mechanism-family map asks which bottleneck a design changes and what evidence would demonstrate that change; it does not rank model families. Readers whose question does not depend on an architecture or optimizer can continue directly to conceptual discovery. Changes to retained context and rollout computation are treated with agent state.
Decoder-only Transformer architecture [ftip-000K]AGENTDRAFTED
Decoder-only Transformer architecture [ftip-000K]AGENTDRAFTED
The continuation law in Definition [ftip-000I] specifies what probabilities a language model exposes. A decoder-only Transformer specifies how a sequence of token identifiers is transformed into those probabilities. This section introduces one component at a time, with dimensions fixed before the component formulas are used.
Notation. Tensor dimensions, positions, heads, and layers [ftip-000L]AGENTDRAFTED
Notation. Tensor dimensions, positions, heads, and layers [ftip-000L]AGENTDRAFTED
Let \(T\) be the maximum token positions processed together, \(d\) the residual-stream width, \(d_{\mathrm {ff}}\) a feed-forward hidden width, \(H\) the number of attention heads, \(d_h\) the query-key width of one head, and \(L\) the number of decoder layers. Positions are indexed by \(t,s\in \{1,\ldots ,T\}\), heads by \(h\in \{1,\ldots ,H\}\), and layers by \(\ell \in \{1,\ldots ,L\}\).
A batch of \(B\) hidden-state sequences is a tensor in \(\mathbb R^{B\times T\times d}\). When the batch coordinate is irrelevant, write \(X\in \mathbb R^{T\times d}\) and let \(X_t\in \mathbb R^d\) denote its row at position \(t\). Matrix products act on the final coordinate.
Definition. Token embedding [vaswani2017attention, sec. 3.4, Embeddings and Softmax] [ftip-000M]AGENTDRAFTED
Definition. Token embedding [vaswani2017attention, sec. 3.4, Embeddings and Softmax] [ftip-000M]AGENTDRAFTED
Let \(\mathcal V\) be the vocabulary of Definition [ftip-000D] and \(d\) the residual width of Notation [ftip-000L]. A token embedding matrix is a learned matrix \(E\in \mathbb R^{|\mathcal V|\times d}\). The hidden vector assigned to token \(a\in \mathcal V\) is the row \(E_a\in \mathbb R^d\).
For a sequence \(x_{1:n}\), embedding lookup produces the matrix \(X^{\mathrm {tok}}\in \mathbb R^{n\times d}\) with row \(X^{\mathrm {tok}}_t=E_{x_t}\). This operation maps token identifiers to vectors; it does not yet encode their positions.
Definition. Embedding-stage positional transformation [ftip-000N]AGENTDRAFTED
Definition. Embedding-stage positional transformation [ftip-000N]AGENTDRAFTED
Using the dimensions of Notation [ftip-000L], an embedding-stage positional transformation is a specified family of position-dependent transformations \(r_t:\mathbb R^d\to \mathbb R^d\), one for each \(t\in \{1,\ldots ,T\}\). Applied after the token embedding of Definition [ftip-000M], it produces the initial hidden vector \[ X^{(0)}_t=r_t(E_{x_t}). \] The family \((r_t)_{t=1}^T\) is part of the architecture, even when it has no learned parameters.
Remark. Where positional information enters [ftip-000O]AGENTDRAFTED
Remark. Where positional information enters [ftip-000O]AGENTDRAFTED
Definition [ftip-000N] covers only mechanisms acting on the hidden vector at the embedding stage. The original Transformer adds a fixed or learned vector \(p_t\) to the token embedding, so \(r_t(z)=z+p_t\); see [vaswani2017attention, §3.5].
Relative-bias methods instead alter an attention score as a function of the displacement \(t-s\). ALiBi gives one such construction in [press2021train, §3].
Rotary position embedding applies position-indexed rotations to queries and keys rather than adding a vector to the residual stream; see RoFormer, Section 3.2, equations (14)--(16) [⧉]. These mechanisms are not interchangeable choices of one tensor: they act at different points in the computation, so a model specification must name the mechanism and placement.
Definition. Query, key, and value projections [vaswani2017attention, sec. 3.2.1] [ftip-000P]AGENTDRAFTED
Definition. Query, key, and value projections [vaswani2017attention, sec. 3.2.1] [ftip-000P]AGENTDRAFTED
Let \(X\in \mathbb R^{T\times d}\) use the notation of Notation [ftip-000L]. For attention head \(h\), choose learned matrices \[ W_h^Q,W_h^K\in \mathbb R^{d\times d_h}, \qquad W_h^V\in \mathbb R^{d\times d_v}, \] where \(d_v\) is the value width of one head. The query, key, and value matrices are \[ Q_h=XW_h^Q,\qquad K_h=XW_h^K,\qquad V_h=XW_h^V. \] Their rows associate a query, key, and value vector with each token position.
Definition. Scaled dot-product attention [vaswani2017attention, sec. 3.2.1, equation (1)] [ftip-000Q]AGENTDRAFTED
Definition. Scaled dot-product attention [vaswani2017attention, sec. 3.2.1, equation (1)] [ftip-000Q]AGENTDRAFTED
Using the head widths in Definition [ftip-000P], let \(T_q,T_k\geq 1\) be query and key-value sequence lengths. For \(Q\in \mathbb R^{T_q\times d_h}\), \(K\in \mathbb R^{T_k\times d_h}\), and \(V\in \mathbb R^{T_k\times d_v}\), scaled dot-product attention is \[ \operatorname {Att}(Q,K,V) =\operatorname {softmax}\left (\frac {QK^{\mathsf T}}{\sqrt {d_h}}\right )V. \] The softmax is applied across each row of the \(T_q\times T_k\) score matrix, so every output row is a convex combination of the value rows.
Example. A two-token attention calculation [ftip-000R]AGENTDRAFTED
Example. A two-token attention calculation [ftip-000R]AGENTDRAFTED
A scalar attention head on two positions makes the masked softmax and its resulting value average explicit.

Take head width \(d_h=1\), so the scale \(1/\sqrt {d_h}\) is one. At position two both keys are causally available. Therefore \[ \operatorname {softmax}(0,\log 3) =\frac {(1,3)}{1+3} =\left (\tfrac 14,\tfrac 34\right ), \qquad z_2=\tfrac 14\cdot 2+\tfrac 34\cdot 6=5. \]
Substitution into the scaled dot-product attention of Definition [ftip-000Q] produces the displayed value. Projection matrices, multiple heads, normalization, and residual connections remain outside this scalar calculation; it represents only one attention operation.
Definition. Causal attention mask [vaswani2017attention, sec. 3.2.3] [ftip-000S]AGENTDRAFTED
Definition. Causal attention mask [vaswani2017attention, sec. 3.2.3] [ftip-000S]AGENTDRAFTED
For a length-\(T\) sequence, the causal attention mask is the matrix \(M\in (\mathbb R\cup \{-\infty \})^{T\times T}\) with \[ M_{ts}= \begin {cases} 0,&s\leq t,\\ -\infty ,&s>t. \end {cases} \] Masked self-attention replaces the score matrix in Definition [ftip-000Q] by \(QK^{\mathsf T}/\sqrt {d_h}+M\). Consequently, the output at position \(t\) has zero attention weight on every later position \(s>t\).
Example. A length-four causal mask [ftip-000T]AGENTDRAFTED
Example. A length-four causal mask [ftip-000T]AGENTDRAFTED
For four positions, a causal mask admits the current and earlier keys and excludes every future key.
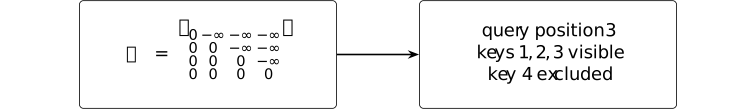
Rows index querying positions and columns index key positions. In row three, the first three entries remain available and the fourth receives \(-\infty \); after softmax the fourth token therefore contributes exactly zero.
The construction is the autoregressive mask of [vaswani2017attention, Section 3.2.3]. It enforces a dependency restriction. Effective use of the available earlier positions is a separate model property.
Definition. Multi-head self-attention [vaswani2017attention, sec. 3.2.2] [ftip-000U]AGENTDRAFTED
Definition. Multi-head self-attention [vaswani2017attention, sec. 3.2.2] [ftip-000U]AGENTDRAFTED
For each head \(h\in \{1,\ldots ,H\}\), form \(Q_h,K_h,V_h\) as in Definition [ftip-000P] from the same input \(X\), and apply the masked attention of Definition [ftip-000S]: \[ Z_h=\operatorname {softmax}\left ( \frac {Q_hK_h^{\mathsf T}}{\sqrt {d_h}}+M \right )V_h. \] With \(W^O\in \mathbb R^{H d_v\times d}\), multi-head self-attention is \[ \operatorname {MHA}(X) =\operatorname {Concat}(Z_1,\ldots ,Z_H)W^O. \] It returns one width-\(d\) vector at every input position.
Remark. Multi-head, grouped-query, and compressed-attention variants [ftip-000V]AGENTDRAFTED
Remark. Multi-head, grouped-query, and compressed-attention variants [ftip-000V]AGENTDRAFTED
The multi-head construction in Definition [ftip-000U] stores a key and value projection per query head. Grouped-query attention instead partitions query heads into groups that share key and value heads; see Ainslie et al., Section 2 [⧉]. This changes parameter and cache shapes while preserving the query-key-value semantics.
Multi-head latent attention first compresses key-value information through a lower-dimensional latent representation and reconstructs head-specific quantities; see DeepSeek-V2, Section 2.1 [⧉]. DeepSeek-V3, Section 2.1, records a later use of that architecture [⧉]. These architectural differences do not establish that their post-training effects equal those of ordinary multi-head attention.
Definition. Positionwise feed-forward sublayer [vaswani2017attention, sec. 3.3, equation (2)] [ftip-000W]AGENTDRAFTED
Definition. Positionwise feed-forward sublayer [vaswani2017attention, sec. 3.3, equation (2)] [ftip-000W]AGENTDRAFTED
With widths \(d\) and \(d_{\mathrm {ff}}\) from Notation [ftip-000L], a positionwise feed-forward sublayer is a map \(F:\mathbb R^d\to \mathbb R^d\) of the form \[ F(z)=\phi (zW_1+b_1)W_2+b_2, \] where \(W_1\in \mathbb R^{d\times d_{\mathrm {ff}}}\), \(W_2\in \mathbb R^{d_{\mathrm {ff}}\times d}\), the vectors \(b_1,b_2\) have the corresponding widths, and \(\phi \) is applied coordinatewise. The same map is applied independently at each token position.
Definition. Sparse mixture-of-experts routing [ftip-000X]AGENTDRAFTED
Definition. Sparse mixture-of-experts routing [ftip-000X]AGENTDRAFTED
Let \(J\geq 1\) and \(1\leq k\leq J\). Let \(F_1,\ldots ,F_J:\mathbb R^d\to \mathbb R^d\) be feed-forward experts and let \(g:\mathbb R^d\to \mathbb R^J\) be a router. For a hidden vector \(z\), let \(S_k(z)\) be the indices of the \(k\) largest coordinates of \(g(z)\), breaking equal scores by a fixed total order on expert indices. A sparse mixture-of-experts layer returns \[ F_{\mathrm {MoE}}(z) =\sum _{j\in S_k(z)}\alpha _j(z)F_j(z), \qquad \alpha _j(z)= \frac {\exp g_j(z)}{\sum _{i\in S_k(z)}\exp g_i(z)}. \] Only the selected experts are evaluated for that token.
Remark. Dense and routed feed-forward computation [ftip-000Y]AGENTDRAFTED
Remark. Dense and routed feed-forward computation [ftip-000Y]AGENTDRAFTED
The dense sublayer in Definition [ftip-000W] evaluates one learned map for every token. The sparsely gated construction of Shazeer et al., Section 2, selects among multiple experts and introduces an additional routing and load-balancing problem [⧉]. The top-\(k\) selection rule is described in Definition [ftip-000X].
Parameter count, active parameter count, and executed operations therefore need not agree. A post-training comparison involving routed models must state which quantity is held fixed and whether the router itself is updated.
Example. Top-k expert routing and its DeepSeek counterpart [ftip-000Z]AGENTDRAFTED
Example. Top-k expert routing and its DeepSeek counterpart [ftip-000Z]AGENTDRAFTED
A routed mixture-of-experts layer uses router scores to activate only a declared subset of routed experts, then combines their outputs with any shared expert path.
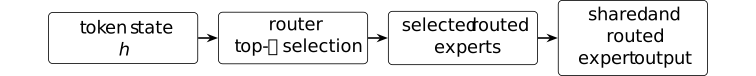
The revision-pinned configuration [⧉] declares \(256\) routed experts, \(6\) experts selected per token, and one shared expert. This instantiates the selection interface while leaving the artifact's router scores, load-balancing mechanism, and expert outputs unspecified.
Definition. Residual connection [vaswani2017attention, sec. 3.1] [ftip-0010]AGENTDRAFTED
Definition. Residual connection [vaswani2017attention, sec. 3.1] [ftip-0010]AGENTDRAFTED
Using the sequence and residual dimensions of Notation [ftip-000L], let \(F:\mathbb R^{T\times d}\to \mathbb R^{T\times d}\) be a sublayer whose input and output have the same shape. A residual connection forms \[ R_F(X)=X+F(X). \] The addition is coordinatewise. Shape equality is part of the construction; the residual path is not a concatenation of features.
Definition. Layer normalization [ba2016layer, sec. 3] [ftip-0011]AGENTDRAFTED
Definition. Layer normalization [ba2016layer, sec. 3] [ftip-0011]AGENTDRAFTED
For the residual width \(d\) of Notation [ftip-000L], a declared numerical stabilizer \(\varepsilon _{\mathrm {LN}}>0\), and \(z=(z_1,\ldots ,z_d)\in \mathbb R^d\), define \(\mu (z)=d^{-1}\sum _i z_i\) and \(\sigma ^2(z)=d^{-1}\sum _i(z_i-\mu (z))^2\). With learned vectors \(\gamma ,\beta \in \mathbb R^d\), layer normalization is \[ \operatorname {LN}(z) =\gamma \odot \frac {z-\mu (z)\mathbf 1} {\sqrt {\sigma ^2(z)+\varepsilon _{\mathrm {LN}}}}+\beta . \] It is applied independently to the hidden vector at each token position. The declared stabilizer makes the numerical operator total on \(\mathbb R^d\); the unstabilized expression is recovered where \(\sigma ^2(z)>0\) by setting \(\varepsilon _{\mathrm {LN}}=0\).
Definition. Normalization placement [ftip-006E]AGENTDRAFTED
Definition. Normalization placement [ftip-006E]AGENTDRAFTED
For a residual stream \(X\), a sublayer \(F\), and a normalization operator \(N\), post-normalization applies \(N(X+F(X))\). In pre-normalization, the sublayer receives a normalized input and the residual update is \(X+F(N(X))\).
Placement is an architecture coordinate, separate from the formula for \(N\). Every decoder block must state which residual branches use which placement.
Definition. Root mean square layer normalization [zhang2019root, Section 4, equation (4)] [ftip-006F]AGENTDRAFTED
Definition. Root mean square layer normalization [zhang2019root, Section 4, equation (4)] [ftip-006F]AGENTDRAFTED
For \(z\in \mathbb R^d\), learned scale \(\gamma \in \mathbb R^d\), and a declared numerical stabilizer \(\varepsilon _{\mathrm {RMS}}>0\), root mean square layer normalization is
\[ \operatorname {RMSNorm}(z) =\gamma \odot \frac {z}{\sqrt {d^{-1}\sum _{i=1}^{d}z_i^2+ \varepsilon _{\mathrm {RMS}}}}. \]Unlike layer normalization in Definition [ftip-0011], this operator does not subtract the coordinate mean. The declared stabilizer makes it total at the zero vector; setting the stabilizer to zero recovers the source expression on nonzero inputs.
Remark. Normalization operator and placement are separate choices [ftip-006G]AGENTDRAFTED
Remark. Normalization operator and placement are separate choices [ftip-006G]AGENTDRAFTED
Ba et al. define layer normalization in [ba2016layer, Section 3]. The original Transformer applies it after residual addition in [vaswani2017attention, Section 3.1]. Xiong et al. distinguish post-normalized and pre-normalized Transformers in [xiong2020layer, Section 3.3]. Either the normalization operator or its placement can change while the other is held fixed.
A later stability statement must therefore name both choices. A result about the normalization formula alone does not determine the residual path.
Definition. Decoder-only Transformer language model [phuong2022formal, sec. 6, Decoder-only transformers] [ftip-0012]AGENTDRAFTED
Definition. Decoder-only Transformer language model [phuong2022formal, sec. 6, Decoder-only transformers] [ftip-0012]AGENTDRAFTED
A decoder-only Transformer language model consists of:
- the token interface in Definition [ftip-000E];
- an initial representation from Definition [ftip-000M] and Definition [ftip-000N];
- a stack of \(L\) causal decoder layers built from the attention, feed-forward, residual, and normalization constructions in Definition [ftip-000S]--Definition [ftip-0011]; and
- an output map from the final hidden vector to token logits.
If the final hidden vector at position \(t\) is \(h_t\in \mathbb R^d\), an output matrix \(W_U\in \mathbb R^{|\mathcal V|\times d}\) and bias \(b_U\in \mathbb R^{|\mathcal V|}\) give logits \(z_t=W_Uh_t+b_U\). The softmax \[ \pi _\theta (a\mid x_{1:t}) =\frac {\exp (z_{t,a})} {\sum _{v\in \mathcal V}\exp (z_{t,v})} \] realizes the conditional next-token law of Definition [ftip-000H]. The parameter tuple \(\theta \) contains every learned tensor named by this architecture.
Example. Decoder-only dataflow and a DeepSeek V4-Flash provenance overlay [ftip-0013]AGENTDRAFTED
Example. Decoder-only dataflow and a DeepSeek V4-Flash provenance overlay [ftip-0013]AGENTDRAFTED
A decoder pipeline maps token identifiers through hidden states to logits; the released model instance and family report provide different evidence about that pipeline.
The pinned configuration [⧉] declares 43 layers, hidden width 4096, 64 attention heads, and one key--value head. Section 2 of the family report [⧉] describes the preview architecture. Neither source identifies a complete 0731-specific architecture or training delta. The diagram records the interface, not a small copy of the released model.
Mechanism families and capability bottlenecks [ftip-00OQ]AGENTDRAFTED
Mechanism families and capability bottlenecks [ftip-00OQ]AGENTDRAFTED
This section compares mechanism families by the capability bottlenecks they change and by the evidence needed to detect those changes. The shared model, task, intervention, cost and evaluation interfaces remain fixed conditions for every claim, while source descriptions, measured results and transfer claims remain separate.
The comparison uses five capability dimensions: state access, the information that can remain available across tokens, steps or external memory operations; adaptive computation, conditional allocation of depth, recurrence, search or stopping together with its charged cost; representation and abstraction, the available representation, composition or predictive state; plasticity, the changes reachable by a declared objective, optimizer, parameter tying and post-training recipe; and portability, survival of a result when the model family, task, scale or deployment regime changes. This is distinct from transfer, which evaluates a frozen artifact on new problems under a common deployment budget. They are coordinates for the capability vector, not a single intelligence scalar.
A bottleneck is the declared resource or interface condition that limits one of these dimensions in a comparison. Cost, numerical stability and monitorability remain evaluation coordinates: the ability to observe the relevant state, compute, update or failure signals under the study protocol. A matched-compute comparison fixes the cost accounting before comparing outcomes; its protocol and the architecture frontier remain authoritative elsewhere in this chapter.
The default core panel contains mechanism families that alter the sequence computation or its state interface. Existing Transformer notation and the decoder-only reference are in § [ftip-000K]; the entries below identify the question each family makes testable.
- Transformer reference. Attention exposes token-indexed content access through the declared context and serves as the baseline for the matched-compute comparison and interface comparisons.
- Selective state-space models. The Mamba construction, Sections 3.1--3.3 makes the state-space parameters input-dependent and computes the resulting time-varying recurrence with a hardware-aware scan. The testable bottleneck is how selective compression trades long-context access and throughput against retrieval and portability boundaries; a source mechanism does not settle that tradeoff.
- Linear attention. The linear-attention formulation, Sections 3.2--3.3 uses a feature-map factorization and associative prefix summaries rather than the full softmax attention matrix. The comparison tests which retrieval and memory tasks preserve their evaluation under the changed state interface; it does not identify every hybrid or recurrent model with pure linear attention.
- Internal-tick and looped models. The Continuous Thought Machine, Sections 3.1--3.5 uses a discrete internal tick dimension, private neuron-level models that process activation histories, synchronization as a latent representation, and standard cross-attention to the input features. Its loss selects minimum-loss and maximum-certainty ticks, making variable internal compute a testable mechanism. The looped computations in § [ftip-00KG] are a separate family; neither is a continuous-time claim, and every extra tick or loop must be charged in the comparison.
- Recurrent or compressed-state mechanisms. The Dragon Hatchling / BDH proposal, Section 3.2 defines a tensor-friendly BDH-GPU state-space system whose attention state admits a reduced representation, alongside local graph dynamics. Its open comparison is whether this state interface supports the target tasks and stable credit assignment at a declared budget; the proposal is not a production result.
- Recurrent feedback. The [zhang2026rlt, Sections 2-3 and 5-8] splits a causal parallel encoder from a recurrent decoder whose previous-token state is fed back into the next token. On finite parity, permutation-tracking, and modular-arithmetic tasks, its reported length extrapolation depends on the feedback ablation and on chunk size. This is evidence for a state-access intervention in a bounded synthetic setting; it does not establish a frontier reasoning gain or a general recurrence law.
- Residual rewrite. [zhang2026deepdelta, Sections 2-4 and 6] replaces an additive residual shortcut with a gated rank-one read/compare/target/write edit. Reported GPT-2 experiments are a finite mechanism observation whose effect remains confounded with residual capacity, compression, and rewrite behavior. A write-only control, capacity-matched control, multiple seeds, and a charged transfer task are needed before attributing a capability change to the rewrite interface.
The recurrent-feedback and residual-rewrite entries are separate intervention arms. Their paired records must expose the changed state or write interface, causal ablations, parameter and token budgets, inference FLOPs, memory, KV/cache or recurrent-state costs, chunking overhead, and monitorability. If the available evidence remains finite-only, the result stays finite-only and does not support ceiling or frontier language.
The adjunct panel changes an objective, temporal law or function-space bias without being interchangeable with the core architecture families. I-JEPA, Section 3 is an encoder/predictor training architecture as well as an embedding-space prediction objective: its context, target and predictor use ViT backbones, the target encoder is updated by exponential moving average, and masked target blocks are predicted from a context block. That predictive objective leaves a specific representation limit: retaining or recovering the latent state does not by itself identify which directions are invariant and which vary across matched observations. SplitJEPA, Sections 3.1--3.4 (the project overview) makes the boundary explicit—predictive recovery can leave a global orthogonal mixing—and resolves it under stationary Gaussian predictive dynamics, a full-rank second moment of variant differences across invariant correspondences, and representation normalization, by identifying invariant and variant subspaces up to within-block isometries without an observation decoder. Here SplitJEPA is a structured JEPA adjunct and a conditional identifiability result, not a general guarantee for I-JEPA. Liquid time-constant networks, Sections 1--2 supply input-dependent continuous dynamics and a numerical ODE-solver interface; the Neural Operator formulation, Sections 1 and 3 supplies a function-space lens with discretization-invariant operator layers. The Zoology study, Sections 3--5 provides controlled recall analyses of sequence mixers. These sources motivate hypotheses and controls; they do not establish a common capability ordering or make an adjunct a replacement architecture. The JEPA comparability interface specifies fields that must be fixed for a JEPA-like comparison; it is not the source of I-JEPA's architecture. Combining CTM's internal dynamics with I-JEPA's encoder/predictor package is a proposed joint intervention, not an established result, and would require separate attribution of both components.
For each panel row, a study should name the changed state or compute interface, the bottleneck dimension, the task and intervention, the evidence type, and the transport boundary. Existing architecture-indexed ceilings and matched compute, published paired measurements (§ [ftip-00KU] and § [ftip-00L4]), conditional frontiers (§ [ftip-00LH]) and study design (§ [ftip-00LS]) provide those controls. Blank, incompatible and unmeasured cells remain findings rather than scores to be filled by intuition.
Architecture-indexed ceilings and matched compute [ftip-00JF]AGENTDRAFTED
Architecture-indexed ceilings and matched compute [ftip-00JF]AGENTDRAFTED
This optional section refines the architecture-neutral capability framework only when the question names an architecture, optimizer, or systems implementation. The general model/interface formulation remains available when these fields are unnecessary.
Architecture comparisons below are conditional on a declared task family, evaluation law, intervention class, and scalar cost. Toy bounds are finite results under their displayed assumptions and do not transfer to concrete model instances without verified interface, task, and cost assumptions.
Architecture, optimizer, and systems variables [ftip-00JG]AGENTDRAFTED
Architecture, optimizer, and systems variables [ftip-00JG]AGENTDRAFTED
Architecture, optimizer, and systems fields refine the model/interface description. A comparison depends only on the fields named in its assumptions and conclusion.
Definition. Optional architecture refinement [ftip-00JH]AGENTDRAFTED
Definition. Optional architecture refinement [ftip-00JH]AGENTDRAFTED
Let \(M\) denote an existing model intervention. An architecture refinement is a record \(A=(\mathcal X,\mathcal Y,\operatorname {Map}_A)\) whose map realizes the same declared input and output interface. Forgetting \(A\) returns \(M\); no architecture claim is made when the field is omitted.
Definition. Optimizer and systems records [ftip-00JI]AGENTDRAFTED
Definition. Optimizer and systems records [ftip-00JI]AGENTDRAFTED
When needed, extend the record by \(O\) for optimizer and state-update rules, and \(S\) for kernels, precision, memory, cache, and scheduling. The triplet \((A,O,S)\) is descriptive; it is not a scalar intelligence score.
Definition. Architecture-indexed evaluation functional [ftip-00JJ]AGENTDRAFTED
Definition. Architecture-indexed evaluation functional [ftip-00JJ]AGENTDRAFTED
Fix an architecture \(A\), its base artifact, a declared intervention set \(\mathfrak I_A\), and the common evaluation interface of Convention [ftip-005D]. Each \(\eta \in \mathfrak I_A\) specifies a protocol \(P_{A,\eta }=\operatorname {PostTrain}(A,\eta )\) in that measurable and absolutely integrable evaluation domain, with real performance \(J_{\rm ev}(P_{A,\eta })\). Let \(c_A(\eta )\in [0,+\infty ]\) be its scalar cost under the study's declared accounting rule: a fixed measured cost or an expected nonnegative cost, as specified. For a finite budget \(C\in \mathbb R_{\geq 0}\), define \[ V_A(C)=\sup \left \{ J_{\rm ev}(P_{A,\eta }): \eta \in \mathfrak I_A,\ c_A(\eta )\leq C \right \}\in \overline {\mathbb R}. \] Infinite-cost interventions are infeasible at every such budget.
As in Definition [ftip-005M], the empty feasible set has value \(-\infty \); an unbounded-above feasible score set has value \(+\infty \). The value is real exactly when that set is nonempty and bounded above. Increasing \(C\) enlarges the feasible set, so \(V_A\) is nondecreasing. A finite supremum need not be attained by any intervention.
Frontier differences and derivatives are ordinary real operations only where the relevant values are finite, with differentiability additionally required for a derivative. Cost ratios use the domain in Definition [ftip-00JP]. The allowed intervention set, evaluation law, and accounting rule are part of the definition, so \(V_A\) is not a universal intelligence function.
Remark. Architecture-neutral projection and gradual complexity [ftip-00JK]AGENTDRAFTED
Remark. Architecture-neutral projection and gradual complexity [ftip-00JK]AGENTDRAFTED
A statement that depends only on the model/interface map is invariant under changes to architecture \(A\), optimizer \(O\), or systems \(S\) that leave that map fixed. A conclusion about one of those fields instead requires assumptions that distinguish its possible values.
Definition. Three ceiling layers [ftip-00JL]AGENTDRAFTED
Definition. Three ceiling layers [ftip-00JL]AGENTDRAFTED
For fixed task and evaluation laws, distinguish the representational ceiling of \(A\), the optimizer-reachable ceiling of \((A,O)\), and the systems-feasible frontier of \((A,O,S,C)\). Each layer is conditional on the objects named; none implies that the next layer attains it.
Definition. Capability vector and conditional frontier [ftip-00JM]AGENTDRAFTED
Definition. Capability vector and conditional frontier [ftip-00JM]AGENTDRAFTED
For an architecture record \(A\), optimizer record \(O\), systems record \(S\), evaluation configuration \(\mathfrak e\) from Definition [ftip-00CE], and declared intervention \(\eta \) at cost cap \(C\), define the capability vector
\[ \mathbf K(A,O,S,\mathfrak e,\eta ,C) =\bigl (K_{\rm state},K_{\rm adapt},K_{\rm repr}, K_{\rm plast},K_{\rm port}\bigr ). \]Its coordinates respectively record state access, adaptive computation, representation and abstraction, plasticity, and portability under the named task, intervention, evaluation law, and cost accounting. A coordinate may be a descriptive field, an estimand, or \(\bot \) when the record is missing, incompatible, or not measured. The tuple is therefore not a common scalar and does not order architectures without a declared comparison rule.
The five coordinates attach to the existing ceiling layers conditionally: representation claims first require a map from \(A\); optimizer-reachable plasticity requires \((A,O)\); state, adaptive computation, and portability claims require the relevant \((A,O,S)\) interface, task family, and deployment regime. A systems-feasible claim also carries \(C\), the cost vector and its declared scalarization. The records in Definition [ftip-00JH], Definition [ftip-00JI], Definition [ftip-00JL], and Definition [ftip-00CE] remain authoritative.
The scalar frontier \(V_A(C)\) of Definition [ftip-00JJ] is a projection onto the declared utility \(J_{\rm ev}\) for one architecture and intervention envelope; it is not a capability coordinate. For a fixed evaluation configuration, a vector-valued study may instead retain the conditional set
\[ \mathcal F_{\mathfrak e}(C) =\operatorname {Pareto}\left \{ \bigl (\mathbf K(A,O,S,\mathfrak e,\eta ,C), J_{\rm ev}(P_{A,\eta }),\mathbf c(P_{A,\eta })\bigr ): c_A(\eta )\leq C \right \}, \]where Pareto dominance is declared for the reported coordinates. The set is conditional on the task, intervention class, evaluation law, cost vector, and missingness rule; it is not a universal intelligence frontier.
The semantic trajectory diagnostic in semantic representation diagnostics supplies a conditional representation record for this vector; its held-out probe score does not fill a function or deployment coordinate.
Matched-compute arms in § [ftip-00JU] compare entries only after stating which coordinates are held fixed, which are allowed to vary, and how the cost vector is charged. Cost, numerical stability, and monitorability remain evaluation coordinates alongside the vector, so a lower scalar cost or a stable implementation is not silently counted as a capability increase.
Depth reuse and latent recurrence [ftip-00KG]AGENTDRAFTED
Depth reuse and latent recurrence [ftip-00KG]AGENTDRAFTED
Repeated depth, latent feedback, and recirculation change the computation performed at inference. Relative to the fixed reference autoregressive Transformer, their costs include any extra passes, state, and prefill work.
Definition. Computation-axis record [ftip-00KH]AGENTDRAFTED
Definition. Computation-axis record [ftip-00KH]AGENTDRAFTED
For an architecture record \(A\), distinguish token steps, feed-forward depth passes, recurrent passes, and latent-state updates. Let \(d(A,r)\) be the declared number of depth passes in run \(r\); it is a computation coordinate, not a synonym for parameter count or reasoning quality.
Remark. Looped Transformers as a source result [ftip-00KI]AGENTDRAFTED
Remark. Looped Transformers as a source result [ftip-00KI]AGENTDRAFTED
Giannou et al. show that a fixed shallow Transformer placed in a loop can execute programmed iterative computations, including conditional branches and in-context algorithms, in Looped Transformers as Programmable Computers[giannou2023looped]. This is a source result under its program, state, and precision assumptions; it is not a universal claim about language-model capability.
Remark. Parameter sharing and width tradeoffs [ftip-00KJ]AGENTDRAFTED
Remark. Parameter sharing and width tradeoffs [ftip-00KJ]AGENTDRAFTED
Xue et al. report that depth sharing can reduce trainable parameters while limiting modeling capacity, and study width and mixture-of-experts remedies in Go Wider Instead of Deeper[xue2021wider]. The comparison is empirical and task-specific; it does not identify a depth-independent ceiling.
Remark. Virtual logical depth and scaling [ftip-00KK]AGENTDRAFTED
Remark. Virtual logical depth and scaling [ftip-00KK]AGENTDRAFTED
Zhu et al. vary virtual logical depth by reusing weights and report reasoning gains at nearly fixed parameter count in Beyond Parameters: Exploring Virtual Logic Depth for Scaling Laws[zhu2025virtualdepth]. Their results motivate a depth coordinate in a scaling study, while leaving knowledge capacity, optimization, and transfer dependent on the declared training and evaluation protocol.
Remark. Recirculation as an inference intervention [ftip-00KL]AGENTDRAFTED
Remark. Recirculation as an inference intervention [ftip-00KL]AGENTDRAFTED
Mozer et al. introduce inference-time recirculation that feeds latent states back through an off-the-shelf model and report task improvements in Recirculation[mozer2026recirculation]. The added serial prefill and adaptive tuning belong in the systems and inference records; the observation is not a proof of a new representational ceiling.
Remark. Latent feedback with a preserved Transformer interface [ftip-00KM]AGENTDRAFTED
Remark. Latent feedback with a preserved Transformer interface [ftip-00KM]AGENTDRAFTED
Wang et al. widen the feedback channel between decoding steps with latent feedback while retaining a Transformer and language-modeling interface in Full-bandwidth transformer[wang2026fullbandwidth]. Any reported token or accuracy savings are conditional on the scheduled multi-pass training and measured decoding cost.
Remark. Latent prediction as a training intervention [ftip-00KN]AGENTDRAFTED
Remark. Latent prediction as a training intervention [ftip-00KN]AGENTDRAFTED
Teoh et al. add next-latent prediction to next-token training and report compact predictive states without changing the Transformer interface in Next-Latent Prediction Transformers Learn Compact World Models[teoh2025nextlatent]. This belongs to the training intervention record, not to an architecture-only comparison.
Example. Equal parameters do not fix effective depth [ftip-00KO]AGENTDRAFTED
Example. Equal parameters do not fix effective depth [ftip-00KO]AGENTDRAFTED
Two runs can share parameter count while using different numbers of recurrent or latent-feedback passes. A matched study must therefore report the computation-axis record and cannot infer an architecture ceiling from parameters alone.
Definition. Depth-reuse model-instance record [ftip-00KP]AGENTDRAFTED
Definition. Depth-reuse model-instance record [ftip-00KP]AGENTDRAFTED
For a depth-reuse comparison, record shared weights, pass count, stopping rule, recurrent state, training objective, token and pass FLOPs, prefill and decode latency, memory, and evaluation seeds. A pass-count change is an intervention even when the parameter tensor is unchanged.
Example. Fixed-recipe depth comparison [ftip-00KQ]AGENTDRAFTED
Example. Fixed-recipe depth comparison [ftip-00KQ]AGENTDRAFTED
In a fixed-recipe arm, hold data, optimizer, feedback, stopping rule, and evaluation law fixed while varying only the declared depth-reuse intervention. The resulting difference is an estimand for that recipe, not a best-achievable comparison.
Remark. Scaling surfaces rather than a single law [ftip-00KR]AGENTDRAFTED
Remark. Scaling surfaces rather than a single law [ftip-00KR]AGENTDRAFTED
A depth-reuse study may fit a surface over parameters, tokens, passes, and cost. The fit is an empirical summary over its measured range; it does not establish an asymptotic law or a universal saturation point.
Remark. Architecture and training are separable records [ftip-00KS]AGENTDRAFTED
Remark. Architecture and training are separable records [ftip-00KS]AGENTDRAFTED
Weight sharing, latent objectives, and recirculation can alter optimization without changing the declared external interface. The comparison must retain architecture, training intervention, and systems coordinates separately.
Remark. Depth reuse across passes, parameters, and tasks [ftip-00KT]AGENTDRAFTED
Remark. Depth reuse across passes, parameters, and tasks [ftip-00KT]AGENTDRAFTED
The cited looped, virtual-depth, latent-feedback, and recirculation results do not show that more passes always improve capability, that parameter sharing dominates added parameters, or that inference-time gains transfer to training or to another task family. Each transfer requires a matched model-instance record.
Ceilings, frontiers, and saturation [ftip-00JN]AGENTDRAFTED
Ceilings, frontiers, and saturation [ftip-00JN]AGENTDRAFTED
Definition. Fixed-recipe and tuned frontiers [ftip-00JO]AGENTDRAFTED
Definition. Fixed-recipe and tuned frontiers [ftip-00JO]AGENTDRAFTED
The fixed-recipe frontier evaluates one common \(\eta \). The equal-tuning frontier permits architecture-specific choices from a predeclared trial set with the same tuning data and budget. The restricted envelope permits a predeclared class of interventions under \(C\). These are distinct estimands.
Definition. Iso-quality cost ratio [ftip-00JP]AGENTDRAFTED
Definition. Iso-quality cost ratio [ftip-00JP]AGENTDRAFTED
For a finite real target \(q\in \mathbb R\) and the frontier of Definition [ftip-00JJ], define the inverse cost \[ C_A(q)=\inf \{C\in \mathbb R_{\geq 0}:V_A(C)\geq q\} \in [0,+\infty ], \qquad \inf \varnothing =+\infty . \] The iso-quality ratio is defined only on the domain \[ \rho _{A/B}(q)=\frac {C_A(q)}{C_B(q)}, \qquad 0\leq C_A(q)<+\infty , \quad 0<C_B(q)<+\infty . \] The architectures must use the same target, evaluation interface, cost units, and comparison arm. The ratio compares efficiency under these choices.
An inverse cost is a threshold infimum, not an executable minimum. The infimum over budgets may be unattained; even if a budget satisfies \(V_A(C)\geq q\), its performance supremum may be unattained at \(q\). An actual target-achieving intervention requires a separate witness.
Positive individual costs do not guarantee a positive inverse cost. For interventions \(\eta _n\), \(n\geq 1\), with score \(1\) and cost \(1/n\), the target \(q=1\) has \(C_A(1)=0\), although every intervention costs more than zero. If both architectures have this family, the putative ratio is \(0/0\) and is excluded by the displayed domain.
Definition. Operational cost vector and scalarization [ftip-00JQ]AGENTDRAFTED
Definition. Operational cost vector and scalarization [ftip-00JQ]AGENTDRAFTED
Record training FLOPs, inference FLOPs, wall time, memory, energy, and hardware separately as \(\mathbf c\). A scalar cost \(C=w\cdot \mathbf c\) is a declared study choice with nonnegative units \(w\); changing \(w\) changes the frontier and must not be hidden as architecture quality.
Theorem. Finite-window representational obstruction [ftip-00JR]AGENTDRAFTED
Theorem. Finite-window representational obstruction [ftip-00JR]AGENTDRAFTED
Consider a causal system whose state after each prefix has at most \(K\) distinct values, and a task with \(K+1\) prefixes requiring pairwise distinct continuation labels. By the pigeonhole principle two prefixes share a state, so at least one continuation label is wrong. This is a finite toy obstruction only; it does not bound a concrete Transformer or KDA instance without a proved reduction to this state model.
Theorem. A conditional saturation certificate [ftip-00JS]AGENTDRAFTED
Theorem. A conditional saturation certificate [ftip-00JS]AGENTDRAFTED
Let \(V_A\) be the nondecreasing frontier of Definition [ftip-00JJ], bounded above by a finite \(U\in \mathbb R\). If an intervention reaches a real target \(q<U\) at a finite cost \(C_q\geq 0\), then at every finite \(C\geq C_q\), \(q\leq V_A(C)\leq U\). In particular \(V_A(C)\) is real and \(0\leq U-V_A(C)\leq U-q\). This elementary certificate is conditional on the bound \(U\); it does not assert that real intelligence saturates.
Example. Equal scalar cost does not identify architecture [ftip-00JT]AGENTDRAFTED
Example. Equal scalar cost does not identify architecture [ftip-00JT]AGENTDRAFTED
Two systems can have the same scalar \(C\) while differing in memory, latency, and training allocation. A cost-weight change can reverse their ordering without changing either system. Thus a one-factor comparison needs a fixed scalarization and a reported cost vector; no architecture effect follows from equal \(C\) alone.
Matched-compute comparison protocol [ftip-00JU]AGENTDRAFTED
Matched-compute comparison protocol [ftip-00JU]AGENTDRAFTED
Definition. Common-recipe comparison arm [ftip-00JV]AGENTDRAFTED
Definition. Common-recipe comparison arm [ftip-00JV]AGENTDRAFTED
A common-recipe arm fixes training data, optimizer family, schedule, post-training procedure and feedback, training and post-training budgets, inference budget, and evaluation protocol and draws. Interface-compatible parameter choices are declared in advance as part of each permitted architecture package. The comparison varies that package under the common recipe; any further deviation is recorded as a separate comparison coordinate. Its score difference measures performance under this recipe, not the best attainable result for either architecture.
Definition. Equal-tuning-budget comparison arm [ftip-00JW]AGENTDRAFTED
Definition. Equal-tuning-budget comparison arm [ftip-00JW]AGENTDRAFTED
An equal-tuning-budget arm permits architecture-specific tuning under a predeclared protocol that fixes the tuning data and its volume, trial count, selection rule, stopping rule, and tuning cost for both architectures. The cost uses the same declared accounting rule. The resulting comparison measures practical performance under this equal optimization effort; it does not determine best possible training or a representation-only limit.
Definition. Restricted-envelope comparison arm [ftip-00JX]AGENTDRAFTED
Definition. Restricted-envelope comparison arm [ftip-00JX]AGENTDRAFTED
A restricted-envelope arm declares an allowed intervention class \(\mathcal E_A\subseteq \mathfrak I_A\) for each architecture, specifying the permitted training, post-training, and inference procedures. The classes expose exclusions, search budgets, seeds, and stopping rules. Restrict the evaluation functional of Definition [ftip-00JJ] to \(\mathcal E_A\) and compare the resulting suprema under the same finite cost cap \(C\geq 0\), common evaluation law, and common declared cost accounting.
The measurable, integrable evaluation domain and extended-real conventions of Definition [ftip-00JJ] apply: an empty feasible class has value \(-\infty \), an unbounded-above feasible score set has value \(+\infty \), and a finite supremum need not be attained. The allowed class is part of the comparison, so its envelope is a restriction-dependent quantity, not an unrestricted architectural ceiling.
Definition. Model-instance comparison evidence record [ftip-00JY]AGENTDRAFTED
Definition. Model-instance comparison evidence record [ftip-00JY]AGENTDRAFTED
A model-instance record contains architecture/checkpoint identity, parameter count, data and post-training recipe, optimizer, precision, hardware, cache policy, training and inference cost vectors, task suite, and independent evaluation seed. A missing field makes an architecture attribution unknown.
Remark. Systems optimizations are measured interventions [ftip-00JZ]AGENTDRAFTED
Remark. Systems optimizations are measured interventions [ftip-00JZ]AGENTDRAFTED
FlashAttention, KV-cache layouts, quantization, batching, and kernels can change feasible cost. If they approximate, truncate, or alter precision of the mathematical computation, the record must mark that as a systems intervention rather than as a pure architecture comparison.
Theorem. Matched-protocol difference is an estimand [ftip-00K0]AGENTDRAFTED
Theorem. Matched-protocol difference is an estimand [ftip-00K0]AGENTDRAFTED
Given \(n\geq 1\) evaluation draws, let \(\widehat V_A(C)\) be the sample mean of finite real evaluation scores for architecture \(A\) at a finite cost cap \(C\geq 0\). Under a fixed evaluation law and common-recipe arm, the finite difference \(\widehat V_A(C)-\widehat V_B(C)\) is a well-defined empirical estimand.
It does not identify a causal architecture effect when data, tuning, or systems coordinates differ. The conclusion follows directly from the declared record.
Remark. Conditions for applying a toy model [ftip-00K1]AGENTDRAFTED
Remark. Conditions for applying a toy model [ftip-00K1]AGENTDRAFTED
A toy theorem applies to a concrete model only if an explicit map from its state and interface to the model preserves the theorem's assumptions, including its cost accounting. Without such a map, the conclusion concerns only the abstract model; its validity for the concrete system is unknown.
Kimi Delta Attention versus Transformer [ftip-00K2]AGENTDRAFTED
Kimi Delta Attention versus Transformer [ftip-00K2]AGENTDRAFTED
Definition. KDA model-instance record [ftip-00K3]AGENTDRAFTED
Definition. KDA model-instance record [ftip-00K3]AGENTDRAFTED
For a Kimi Delta Attention (KDA) versus full-attention baseline study, record the exact Kimi Linear checkpoint, layer mix, context length, hardware, kernel, precision, batch, and decoding workload. The paper describes KDA as a fine-grained gated delta-rule module in a hybrid architecture; those are source observations from Kimi Linear: An Expressive, Efficient Attention Architecture[kimi2025linear], not universal theorems.
If the baseline is called a Transformer, record whether it is the paper's MLA baseline or another full-attention implementation; the label alone does not identify a common architecture or cost.
Example. Matched-cost KDA and Transformer comparison [ftip-00K4]AGENTDRAFTED
Example. Matched-cost KDA and Transformer comparison [ftip-00K4]AGENTDRAFTED
A matched comparison uses the same task prompts, post-training data and feedback, optimizer family, evaluation protocol, and quality target. The corresponding measurements include parameter count, training FLOPs, inference FLOPs, wall time, memory, KV-cache bytes, and context length for each architecture. A reported speed or quality difference is conditional on these experimental conditions and measurements.
Remark. What the Kimi Linear paper establishes [ftip-00K5]AGENTDRAFTED
Remark. What the Kimi Linear paper establishes [ftip-00K5]AGENTDRAFTED
Kimi Linear reports a hybrid KDA/MLA model and fair-comparison experiments in Sections 3--5, with setup in Section 5.4 and efficiency comparisons in Sections 5.5--5.6 of Kimi Linear: An Expressive, Efficient Attention Architecture[kimi2025linear]. These include long-context efficiency.
The reported throughput and quality are empirical under its training recipe and hardware; they are lower bounds on demonstrated performance, not an architecture-independent ceiling.
Example. Parameter matching is not cost matching [ftip-00K6]AGENTDRAFTED
Example. Parameter matching is not cost matching [ftip-00K6]AGENTDRAFTED
Two models with equal parameter count can have different attention FLOPs, KV-cache memory, kernel utilization, and attainable context. Conversely, equal wall time can hide different hardware and precision. Therefore a parameter-matched result cannot by itself identify a compute frontier.
Remark. Cache, throughput, and quality in KDA comparisons [ftip-00K7]AGENTDRAFTED
Remark. Cache, throughput, and quality in KDA comparisons [ftip-00K7]AGENTDRAFTED
The KDA example does not prove that every linear-attention model beats every Transformer, that cache savings imply equal quality, or that a measured throughput gain is a capability gain. Any such statement requires a new matched study with the evidence record of Definition [ftip-00JY].
Definition. Model-instance comparison decision rule [ftip-00K8]AGENTDRAFTED
Definition. Model-instance comparison decision rule [ftip-00K8]AGENTDRAFTED
Call architecture A more cost-efficient than B at quality \(q\) only when the compared threshold costs use the same declared protocol, the confidence procedure and stopping rule are fixed, and all cost-vector coordinates needed by the claim are present. A ratio additionally requires finite costs and a strictly positive denominator as in Definition [ftip-00JP]. State whether the costs are measured target-achieving witnesses or justified inverse-frontier values \(C_A(q)\) and \(C_B(q)\); observing one successful run does not identify those infima. Otherwise the comparison is descriptive or unknown.
Interface boundaries for alternative architectures [ftip-00K9]AGENTDRAFTED
Interface boundaries for alternative architectures [ftip-00K9]AGENTDRAFTED
Definition. JEPA comparability interface [ftip-00KA]AGENTDRAFTED
Definition. JEPA comparability interface [ftip-00KA]AGENTDRAFTED
A JEPA-like architecture is comparable to an autoregressive model only after fixing the predictor, target representation, decoder or downstream interface, training objective, inference procedure, and evaluation law. A parameter-count match alone is not a typed comparison.
Remark. Representation and task interface are separate [ftip-00KB]AGENTDRAFTED
Remark. Representation and task interface are separate [ftip-00KB]AGENTDRAFTED
A latent predictor can be excellent under one decoder and unusable under another. The evaluation record must therefore include the interface that maps the representation to the declared task output.
Theorem. Interface-preserving architecture reduction [ftip-00KC]AGENTDRAFTED
Theorem. Interface-preserving architecture reduction [ftip-00KC]AGENTDRAFTED
If two architecture records induce the same conditional output law on a fixed task and evaluation interface, every evaluation functional \(J\) gives the same value. This is an immediate pushforward identity under the stated output-law and interface assumptions. It does not imply that distinct architectures are generally equivalent.
Example. Equal benchmark score can hide different ceilings [ftip-00KD]AGENTDRAFTED
Example. Equal benchmark score can hide different ceilings [ftip-00KD]AGENTDRAFTED
Two architectures may tie on a finite benchmark while differing on an unmeasured task slice or longer context. Thus a single score cannot establish equal representational ceilings; the task family and evaluation coverage must be declared.
Remark. Architecture-independent model interfaces [ftip-00KE]AGENTDRAFTED
Remark. Architecture-independent model interfaces [ftip-00KE]AGENTDRAFTED
A result stated solely in terms of a model/interface map applies to every architecture realizing that map and satisfying its hypotheses. An architecture-specific conclusion can require further assumptions, as in Remark [ftip-00JK].
Remark. Open model-instance questions [ftip-00KF]AGENTDRAFTED
Remark. Open model-instance questions [ftip-00KF]AGENTDRAFTED
The relative capability and cost of KDA, full attention, and JEPA candidates remain empirical questions. A reproducible comparison requires identified checkpoints or reproducible training, fixed evaluation seeds, and measured cost vectors. Architecture-specific ceilings remain estimands and hypotheses rather than established constants.
Published hybrid-attention comparison [ftip-00KU]AGENTDRAFTED
Published hybrid-attention comparison [ftip-00KU]AGENTDRAFTED
Kimi Linear combines recurrent KDA layers with periodic full MLA attention. Its published comparison shows task-dependent score changes and lower long-context decoding times. The selected scores in Example [ftip-00LC], the memory estimate in Example [ftip-00KY], and the discovery calculation in Example [ftip-00L3] connect these observations to a post-training question: when can a cheaper attempt compensate for a possible lower per-attempt success probability?
Example. Published Kimi Linear operating point [ftip-00KV]AGENTDRAFTED
Example. Published Kimi Linear operating point [ftip-00KV]AGENTDRAFTED
The Kimi Linear report compares experimental models pretrained on 1.4 trillion tokens, each with 48 billion total and 3 billion active parameters. Kimi Linear uses three Kimi Delta Attention layers for each full Multi-head Latent Attention layer, with no positional encoding (NoPE) in its MLA layers; the reference uses full MLA attention [kimi2025linear, Sections 4 and 5.4]. These are properties of the reported hybrid architecture.
These experimental models are distinct from the released Kimi Linear model, pretrained on 5.7 trillion tokens and supporting up to one million tokens of context. Appendix D compares that release with Moonlight, which has 16 billion total and 3 billion active parameters [kimi2025linear, Section 5.4.1 and Appendix D].
Example. Published efficiency observations [ftip-00KW]AGENTDRAFTED
Example. Published efficiency observations [ftip-00KW]AGENTDRAFTED
For batch size one at one million tokens, Figure 7 labels a \(2.9\times \) prefill speedup and a \(2.2\times \) decoding speedup for Kimi Linear against MLA. Section 6.3 gives \(2.3\times \) for the latter point, so the graphic and prose differ slightly [kimi2025linear, Figure 7 and Sections 5.6 and 6.3].
The larger-batch comparison in Figure 1(b) gives decoding time per output token of 1.84 milliseconds for Kimi Linear and 11.48 milliseconds for MLA, with a reported \(6.3\times \) speedup. Section 6.3 describes this as a theoretical speedup from reallocating saved KV-cache memory to larger batches. It illustrates a different use of the memory saving from the batch-one latency result [kimi2025linear, Figure 1(b) and Section 6.3].
Figure 1(a) reports RULER scores of 84.3 for Kimi Linear and 81.3 for MLA at 128k context, with \(3.98\times \) decoding acceleration [kimi2025linear, Figure 1(a)]. The report also gives a reduction of up to 75 percent in KV-cache use [kimi2025linear, Abstract]. Together these observations motivate studying context length and batch size as separate cost coordinates. The unequal RULER scores and different timing regimes are retained when interpreting those points.
Definition. Quality target and cost measurement [ftip-00KX]AGENTDRAFTED
Definition. Quality target and cost measurement [ftip-00KX]AGENTDRAFTED
For a reported benchmark score q, use the same task, prompt law, scoring rule, and post-training condition for both systems. The comparison records the smallest measured cost at which each system reaches q, when such a measurement exists. A throughput or cache ratio is not substituted for this iso-quality cost.
Example. A cache-memory estimate for hybrid attention [ftip-00KY]AGENTDRAFTED
Example. A cache-memory estimate for hybrid attention [ftip-00KY]AGENTDRAFTED
The cited FLA KDA implementation at commit 6b6f546f stores one active recurrent state
per sequence, with dimensions determined by the value heads and key/value
dimensions rather than accumulated context length. Its newly allocated
state uses float32
[⧉].
The optional short-convolution state has one fixed-width kernel buffer per
channel and sequence
[⧉].
This supplies a concrete implementation model for the recurrent part of
the 3:1 mixture in Example [ftip-00KV].
Consider a stylized comparison with \(4\ell \) layers, batch size \(b\), and context length \(T\), where \(\ell ,b,T\) are positive integers. Assume each MLA layer stores \(\kappa T\) bytes per sequence, with the same \(\kappa >0\) in both designs, and each KDA layer stores one terminal recurrent-plus-convolution state of \(\sigma >0\) bytes. The active attention-state memories are
\[ M_{\rm MLA}=4b\ell \kappa T,\qquad M_{\rm hybrid}=b\ell (\kappa T+3\sigma ),\qquad \frac {M_{\rm hybrid}}{M_{\rm MLA}} =\frac {1}{4}+\frac {3\sigma }{4\kappa T}. \]The hybrid uses less active state exactly when \(T>\frac {\sigma }{\kappa }\), and the ratio tends to \(1/4\) as context grows. This explains why replacing three quarters of the growing caches can approach a 75-percent saving, while fixed recurrent-state overhead can erase the advantage at short contexts. The retained MLA layers keep the hybrid's state memory linear in \(T\); the whole model is not a fixed-memory recurrent system.
Weights, training activations, workspaces, allocator padding and saved prefix states are outside this active-state calculation. At a fixed device memory budget, the estimate predicts more room for simultaneous or longer rollouts when attention state dominates. It does not predict a fourfold speedup. Training and decoding also use different execution paths: FLA selects chunk kernels for gradient-enabled computation and fused recurrence for short inference calls [⧉]. The fixed-state estimate is therefore a useful serving hypothesis, not a training-memory or training-speed formula.
Example. Common-recipe reading of the Kimi result [ftip-00KZ]AGENTDRAFTED
Example. Common-recipe reading of the Kimi result [ftip-00KZ]AGENTDRAFTED
The report holds its stated pretraining and SFT recipes common across the experimental models [kimi2025linear, Sections 5.4--5.5 and Table 4]. The selected observations in Example [ftip-00LC] compare the resulting trained designs, including the hybrid's 3:1 KDA/MLA pattern and NoPE choice. The mixed score directions suggest a task-dependent tradeoff rather than one ordering of the two architectures.
The theoretical mechanism is a change in the cost of maintaining and using the prefix: recurrent layers compress it into state, while the retained MLA layers preserve growing attention caches. The model in Example [ftip-00KY] predicts the largest memory advantage at long contexts. If this advantage reduces the cost of generating useful candidates, Example [ftip-00L3] predicts when more attempts can offset a reduction in per-attempt quality. This is a conditional explanation to test through rollout costs and verified success rates; it does not require attributing the whole result to KDA alone.
Example. Measured iso-quality cost ratio [ftip-00L0]AGENTDRAFTED
Example. Measured iso-quality cost ratio [ftip-00L0]AGENTDRAFTED
Let \(c_K(q)\) and \(c_T(q)\) be measured inference costs for Kimi Linear and the Transformer reference at the same finite real score \(q\) and context length, under one accounting rule. If \(0\leq c_K(q)<+\infty \) and \(0<c_T(q)<+\infty \), the measured ratio \(\widehat \rho _{K/T}(q)=c_K(q)/c_T(q)\) is reported together with the full cost vectors. These measured costs need not be the inverse frontier infima of Definition [ftip-00JP]. If either threshold is unmeasured or the denominator is zero, the ratio is left undefined rather than inferred from the paper's speedup plot.
Remark. Hybrid attention is not pure linear attention [ftip-00L1]AGENTDRAFTED
Remark. Hybrid attention is not pure linear attention [ftip-00L1]AGENTDRAFTED
Kimi Linear combines KDA with periodic full-attention layers. A measured advantage therefore identifies the reported hybrid intervention, not a claim that a purely linear recurrent architecture has the same quality or ceiling. The layer pattern belongs in the architecture record.
Remark. Demonstrated performance is a lower bound [ftip-00L2]AGENTDRAFTED
Remark. Demonstrated performance is a lower bound [ftip-00L2]AGENTDRAFTED
The published benchmark scores demonstrate attainable points for the reported checkpoints and protocol. They do not establish a representational ceiling, a universal scaling law, or a claim that additional cost cannot improve either architecture.
Example. When cheaper attempts compensate for lower success [ftip-00L3]AGENTDRAFTED
Example. When cheaper attempts compensate for lower success [ftip-00L3]AGENTDRAFTED
Smaller caches can support more concurrent requests or avoid preemption and recomputation. These are actual serving mechanisms in vLLM's memory and scheduling guidance [⧉]. For post-training, the useful prediction is therefore about completed candidate attempts under a budget, including verification and optimization costs, rather than decoding speed alone.
Use the following cost model on the same hardware. One baseline attempt costs \(c>0\); generation accounts for a fraction \(f\in [0,1]\). Suppose generation becomes \(s_{\rm gen}>0\) times as fast while all other cost per attempt stays fixed. The new cost and total attempt-throughput factor are
\[ c_K=c\left (1-f+\frac {f}{s_{\rm gen}}\right ),\qquad S=\frac {c}{c_K} =\frac {1}{1-f+f/s_{\rm gen}}. \]For a fixed budget \(B\geq 0\), this model permits \(N_M=\lfloor B/c\rfloor \) baseline attempts and \(N_K=\lfloor B/c_K\rfloor \) hybrid attempts. Assume \(N_M,N_K\geq 1\) and verified-success events independent within each set of attempts, with respective probabilities \(p_M,p_K\in [0,1]\). Then Theorem [ftip-0078] gives discovery probabilities \(1-(1-p_M)^{N_M}\) and \(1-(1-p_K)^{N_K}\). The hybrid matches or exceeds baseline discovery exactly when
\[ p_K\geq 1-(1-p_M)^{N_M/N_K}. \]This follows by comparing the two failure probabilities and taking the nonnegative \(N_K\)-th root.
For an illustrative estimate, suppose generation consumes 80 percent of the baseline cost and use \(s_{\rm gen}=2.2\), motivated by the batch-one decode figure in Example [ftip-00KW]. Applying that decode factor to the whole generation stage is a working approximation, not a measured rollout result. Then \(S\approx 1.774\); a budget of \(B=10c\) buys 10 baseline attempts or 17 hybrid attempts. If \(p_M=0.10\) and \(p_K=0.08\), the discovery probabilities are approximately \(0.651\) and \(0.758\). The break-even hybrid probability is about \(0.0601\). Thus this model predicts that more attempts can outweigh a moderate per-attempt quality loss. The assumed probabilities are illustrative verified-success rates, not conversions of the benchmark scores in Example [ftip-00LC].
The prediction is strongest for long-context, generation-heavy work whose saved memory becomes usable rollout capacity. As verification or optimization dominates, \(f\) shrinks and \(S\) approaches one. Correlated attempts require the joint-law analysis of Convention [ftip-0077] instead of the independent product. Measure completed attempts, verified-success rates and total cost under a fixed prompt, decoding and verifier protocol to test the tradeoff. In the RLVR round of Example [ftip-004M], additional successful candidates can improve the available feedback; whether they produce useful accepted updates is a further optimizer-and-evaluation question, as Example [ftip-0085] demonstrates.
Paired measurements for model comparison [ftip-00L4]AGENTDRAFTED
Paired measurements for model comparison [ftip-00L4]AGENTDRAFTED
A paired measurement specifies both model instances and their task, intervention, evaluation, and cost coordinates. These conditions determine the meaning of each point in the measured frontier.
Definition. Comparison pair identity [ftip-00L5]AGENTDRAFTED
Definition. Comparison pair identity [ftip-00L5]AGENTDRAFTED
A paired comparison identifies the two systems, exact checkpoint or training commit, architecture variant, parameter counts, tokenizer, and context limit. A label such as ``Transformer'' is insufficient when attention, cache, or layer patterns differ.
Definition. Common task and evaluation conditions [ftip-00L6]AGENTDRAFTED
Definition. Common task and evaluation conditions [ftip-00L6]AGENTDRAFTED
Both systems use the same task family, prompt and data law, scoring rule, sampling seeds, stopping rule, and evaluator version. Any exception is a separate comparison arm, not an unrecorded architecture effect.
Definition. Training and post-training coordinates [ftip-00L7]AGENTDRAFTED
Definition. Training and post-training coordinates [ftip-00L7]AGENTDRAFTED
Record data volume, token order policy, optimizer and schedule, supervised tuning, feedback or reinforcement procedure, update count, and selection rule. The common-recipe arm fixes these coordinates; the equal-tuning arm allows predeclared alternatives with equal search resources.
Definition. Inference and systems coordinates [ftip-00L8]AGENTDRAFTED
Definition. Inference and systems coordinates [ftip-00L8]AGENTDRAFTED
Record hardware, software and kernel versions, precision, batch, cache policy, sequence lengths, warm-up procedure, concurrency, and decoding settings. A kernel or cache change that alters numerical computation is marked as an intervention rather than hidden as an implementation detail.
Definition. Per-system cost vector [ftip-00L9]AGENTDRAFTED
Definition. Per-system cost vector [ftip-00L9]AGENTDRAFTED
For each system, the cost vector \(\mathbf c\) contains training FLOPs, inference FLOPs, wall time, memory, energy when available, and context length. The primary scalar \(C\) and its weights are declared beside the vector; omitted coordinates are marked unknown.
Definition. Repeated measurement rule [ftip-00LA]AGENTDRAFTED
Definition. Repeated measurement rule [ftip-00LA]AGENTDRAFTED
For each fixed workload and system, record warm-up runs, repetition count, random seeds, and the aggregation rule. Report mean and dispersion for time, memory, and score; a single fastest run cannot define a cost frontier.
Definition. Paired uncertainty estimates [ftip-00LB]AGENTDRAFTED
Definition. Paired uncertainty estimates [ftip-00LB]AGENTDRAFTED
When the same evaluation items are used, report paired score differences and an uncertainty procedure fixed before inspecting the result. Confidence intervals quantify sampling variation; they do not repair unmatched training, systems, or task coordinates.
Example. Published Kimi Linear comparison [ftip-00LC]AGENTDRAFTED
Example. Published Kimi Linear comparison [ftip-00LC]AGENTDRAFTED
Table 4 of the Kimi Linear report compares the experimental models pretrained on 1.4 trillion tokens in Example [ftip-00KV], after the same supervised fine-tuning (SFT) recipe. Both have 48 billion total and 3 billion active parameters. Three selected benchmark scores are [kimi2025linear, Sections 4 and 5.4 and Table 4]:
| Arm | MMLU-Pro | LiveBench | EvalPlus |
|---|---|---|---|
| Kimi Linear | 67.4 | 45.2 | 61.0 |
| Full MLA | 65.7 | 45.7 | 62.6 |
The entries use the paper's score units, with larger values better on each selected benchmark; LiveBench is reported as Pass@1. Kimi Linear is higher on MMLU-Pro and lower on LiveBench and EvalPlus in these observations. These are reported point estimates on different tasks, not a single capability score; the table supplies no uncertainty estimate.
The common recipe uses the K2 pretraining corpus, MuonClip and a shared training schedule. SFT proceeds from broad instruction data to targeted reasoning tasks; evaluation uses temperature 1.0 and an internal framework derived from LM-Harness [kimi2025linear, Section 5.4]. Thus the scores provide a concrete example of how the trained hybrid and full-MLA designs respond to the same recipe. The cost mechanism and its possible post-training consequences are developed in Example [ftip-00KZ].
Remark. Measured and assumed costs [ftip-00LD]AGENTDRAFTED
Remark. Measured and assumed costs [ftip-00LD]AGENTDRAFTED
A useful cost model can combine measurements with assumptions justified by the architecture and its implementation. In Example [ftip-00L3], the generation share \(f\) and speed factor \(s_{\rm gen}\) determine a predicted attempt-throughput factor. Their assumed values can be varied without pretending they were measured in the original experiment.
For fixed \(f\in [0,1]\), write \(S(s)=1/(1-f+f/s)\) for \(s>0\). This function is nondecreasing. An interval \(s_{\rm gen}\in [s_-,s_+]\), with \(0<s_-\leq s_+\), therefore gives the conditional range \(S\in [S(s_-),S(s_+)]\). This is sensitivity to a chosen assumption range; it is a statistical confidence interval only if a sampling argument supplies that interpretation.
Definition. Measured contrasts and conditional predictions [ftip-00LE]AGENTDRAFTED
Definition. Measured contrasts and conditional predictions [ftip-00LE]AGENTDRAFTED
A measured paired contrast evaluates the same declared quantity for two observed model instances under a specified task, protocol and cost accounting. The common-recipe scores in Example [ftip-00LC] are one example. A confirmatory comparison fixes its matching and selection rules before examining the scores.
A conditional paired prediction instead uses an explicit model to supply one or more cost or response quantities, then derives the comparison under those assumptions. The discovery probabilities in Example [ftip-00L3] are an example. Such a prediction can be motivated by existing observations and guide a later experiment; its unmeasured inputs remain assumptions, and agreement with new matched measurements tests the model.
Example. How generation share changes the predicted gain [ftip-00LF]AGENTDRAFTED
Example. How generation share changes the predicted gain [ftip-00LF]AGENTDRAFTED
Keep the illustrative generation factor \(s_{\rm gen}=2.2\) from Example [ftip-00L3] and vary the baseline generation share \(f\). Its cost model gives the following total attempt-throughput factors:
| Generation share | Predicted throughput factor |
|---|---|
| 20 percent | 1.122 |
| 50 percent | 1.375 |
| 80 percent | 1.774 |
| 100 percent | 2.200 |
These calculated values show why the same decoding improvement can matter much more for generation-heavy search than for a verifier- or optimizer-dominated workload. They suggest measuring the time spent in generation, verification and updates before selecting where to invest systems effort. A change in the bottleneck changes the useful intervention, even when the attention architecture stays fixed.
Remark. Testing the predicted architecture tradeoff [ftip-00LG]AGENTDRAFTED
Remark. Testing the predicted architecture tradeoff [ftip-00LG]AGENTDRAFTED
The memory and discovery models predict the strongest benefit when long prefixes make attention state expensive, saved capacity improves useful rollout throughput, and per-attempt success remains above the break-even threshold. Short contexts, expensive verification, or strongly correlated attempts can weaken that benefit. These are distinct mechanisms to test, rather than a universal ranking of KDA and full attention.
A comparison across implementations can retain this reasoning while re-estimating state sizes, generation share and success probabilities for the new system. Report both the prediction and the matched measurements: their agreement or disagreement identifies which mechanism or assumption needs revision.
Conditional frontier and saturation analysis [ftip-00LH]AGENTDRAFTED
Conditional frontier and saturation analysis [ftip-00LH]AGENTDRAFTED
A finite matched study measures capability at selected values of one declared cost. Its frontier and saturation target are conditional on that protocol; they do not establish a universal intelligence law.
Definition. Finite cost grid [ftip-00LI]AGENTDRAFTED
Definition. Finite cost grid [ftip-00LI]AGENTDRAFTED
Choose a finite ordered grid \(0<C_1<\cdots <C_m\) and evaluate each architecture at every declared grid point under the same task and protocol. The resulting values \(\widehat V_A(C_i)\) are observations of the restricted frontier, not its values between grid points.
Definition. Observed upper envelope [ftip-00LJ]AGENTDRAFTED
Definition. Observed upper envelope [ftip-00LJ]AGENTDRAFTED
For an observed score \(s_A(C_i)\) define the discrete upper envelope \(U_A(C_i)=\max _{j\leq i}s_A(C_j)\). It is a descriptive monotone summary of the measured points; it is not evidence that unmeasured costs attain the envelope or that extra cost cannot reduce score.
Definition. Uncertainty bands on the frontier [ftip-00LK]AGENTDRAFTED
Definition. Uncertainty bands on the frontier [ftip-00LK]AGENTDRAFTED
Attach a predeclared uncertainty interval \(I_A(C_i)\) to each score and carry those intervals through score differences and threshold crossings. A finite band describes sampling and measurement variation; it does not cover unmeasured training procedures or architectures.
Definition. Declared saturation target [ftip-00LL]AGENTDRAFTED
Definition. Declared saturation target [ftip-00LL]AGENTDRAFTED
Fix a quality target \(q\in \mathbb R\), tolerance and cost increment \(\varepsilon ,\delta \in (0,+\infty )\), and a budget \(C\in \mathbb R_{\geq 0}\). Require both \(V_A(C)\) and \(V_A(C+\delta )\) to be finite real values. A study calls an architecture \(\varepsilon \)-saturated at \(C\) only relative to its allowed intervention class when the restricted frontier has certified gain \(V_A(C+\delta )-V_A(C)\leq \varepsilon \).
Theorem. Conditional saturation certificate [ftip-00LM]AGENTDRAFTED
Theorem. Conditional saturation certificate [ftip-00LM]AGENTDRAFTED
Take finite real \(U\), \(C\geq 0\), \(\delta \geq 0\), and \(\varepsilon \geq 0\), with the nondecreasing frontier of Definition [ftip-00JJ]. If a justified upper bound gives \(V_A(C+\delta )\leq U\) and a justified lower bound gives \(V_A(C)\geq U-\varepsilon \), then \(U-\varepsilon \leq V_A(C)\leq V_A(C+\delta )\leq U\). Both endpoint values are therefore finite real, and \(0\leq V_A(C+\delta )-V_A(C)\leq \varepsilon \). This is a conditional bound for the named frontier; it proves no universal saturation of intelligence.
For the finite controller class with hard resource admission, Corollary [ftip-00MC] obtains the required bounds from a feasible controller and a uniform Bellman certificate.
Example. Finite observations need not identify a frontier [ftip-00LN]AGENTDRAFTED
Example. Finite observations need not identify a frontier [ftip-00LN]AGENTDRAFTED
Let \(S\subset \mathbb R_{\geq 0}\) be a finite set of measured costs, and choose \(C_0>0\) larger than every element of \(S\). Suppose the exact frontier value observed at each cost in \(S\) is zero. For finite budgets \(C\geq 0\), suppose the declared class of possible frontiers permits both \[ V_0(C)=0, \qquad V_1(C)= \begin {cases} 0,&0\leq C<C_0,\\ 1,&C\geq C_0. \end {cases} \] These nondecreasing frontiers with scores in \([0,1]\) agree on every observed cost and differ at \(C_0\). The observations alone do not distinguish them.
Both possibilities have finite realizations in the framework of Definition [ftip-00JJ]: allow two interventions with costs \(0\) and \(C_0\). Give the first score zero and the second score \(\theta \in \{0,1\}\). For example, on a single deterministic evaluation task with utility equal to the output bit, let the two resulting protocols return \(0\) and \(\theta \). The two possible choices of \(\theta \) give \(V_0\) and \(V_1\), respectively, under the same intervention and cost specification. Every score is finite, and the feasible score maximum is attained at each budget.
This example does not supply a strictly better agreeing frontier for every possible data set or every admissible class. If a proved global score bound is \(1\) and an intervention attains it at a finite cost \(C_*\geq 0\), monotonicity forces \(V_A(C)=1\) for every \(C\geq C_*\); no higher value is admissible. A singleton class of possible frontiers can also identify the frontier without such an alternative. A conditional certificate such as Theorem [ftip-00LM] therefore requires its stated upper-bound evidence; that evidence does not follow merely from the absence of an observed improvement.
Definition. One-factor cost interpretation [ftip-00LO]AGENTDRAFTED
Definition. One-factor cost interpretation [ftip-00LO]AGENTDRAFTED
The primary cost \(C\) is a declared scalarization of the recorded cost vector. A frontier statement is conditional on its units and weights; the same paired measurements may produce a different ordering under a different scalarization.
Example. Crossing architecture frontiers [ftip-00LP]AGENTDRAFTED
Example. Crossing architecture frontiers [ftip-00LP]AGENTDRAFTED
Two architectures may alternate in the observed ordering across costs: one can score higher at small \(C\) while the other catches up at larger \(C\). Thus a single comparison point cannot establish a global ordering or a common ceiling.
Example. Frontier report for the KDA study [ftip-00LQ]AGENTDRAFTED
Example. Frontier report for the KDA study [ftip-00LQ]AGENTDRAFTED
A Kimi Delta Attention versus Transformer study should publish the cost grid, paired scores, uncertainty intervals, scalarization weights, and the exact identities and configurations of the compared models. The report may then state which measured points are Pareto or iso-quality comparisons under that protocol.
Remark. Frontiers depend on the intervention and evaluation [ftip-00LR]AGENTDRAFTED
Remark. Frontiers depend on the intervention and evaluation [ftip-00LR]AGENTDRAFTED
The conditional frontier is indexed by architecture, intervention class, task family, evaluation law, and cost scalarization. Changing any of these coordinates creates a new estimand; no ordering transfers automatically to a new checkpoint, optimizer, hardware stack, or task family.
Study design for comparisons across model instances [ftip-00LS]AGENTDRAFTED
Study design for comparisons across model instances [ftip-00LS]AGENTDRAFTED
This subsection specifies how a conditional architecture comparison may be instantiated without changing the architecture-neutral formulation. It is a study design, not a universal ranking of architectures.
Definition. Matched model-instance record [ftip-00LT]AGENTDRAFTED
Definition. Matched model-instance record [ftip-00LT]AGENTDRAFTED
A model-instance record names the architecture, parameterization or checkpoint, training and post-training recipe, optimizer, execution stack, inference budget, task family, evaluation law, and recorded cost vector. Two records are comparable only after the fields held fixed and the fields allowed to vary are declared.
Definition. Pair identity and comparison unit [ftip-00LU]AGENTDRAFTED
Definition. Pair identity and comparison unit [ftip-00LU]AGENTDRAFTED
A comparison unit is a pair of model-instance records evaluated on the same task family and evaluation law, together with a declared cost scalarization. A Transformer reference and a Kimi Delta Attention instance may form such a pair only when the remaining coordinates are documented.
Remark. Paired responses to a common recipe [ftip-00LV]AGENTDRAFTED
Remark. Paired responses to a common recipe [ftip-00LV]AGENTDRAFTED
For a pair of matched model-instance records, the common-recipe arm measures how the permitted architecture packages respond to one recipe. A score advantage in this comparison need not persist after either package is retuned.
Remark. Different recipes under equal tuning effort [ftip-00LW]AGENTDRAFTED
Remark. Different recipes under equal tuning effort [ftip-00LW]AGENTDRAFTED
Under the equal-tuning-budget arm, the two selected model instances may use different recipes. That difference is compatible with equal predeclared tuning effort; forcing the selected recipes to match would answer a different comparison question.
Remark. How an allowed class changes its envelope [ftip-00LX]AGENTDRAFTED
Remark. How an allowed class changes its envelope [ftip-00LX]AGENTDRAFTED
In the restricted-envelope arm, enlarging an allowed intervention class at fixed evaluation law, cost accounting, and budget can raise its envelope and cannot lower it. A finite search over feasible interventions supplies a lower bound from the scores it attains. It certifies the supremum only if it covers every feasible intervention or is accompanied by a matching upper-bound argument.
Remark. Coordinate-change rule [ftip-00LY]AGENTDRAFTED
Remark. Coordinate-change rule [ftip-00LY]AGENTDRAFTED
Changing the optimizer, post-training method, hardware or kernel, precision, context policy, or evaluation law changes a comparison coordinate. A score difference after such a change belongs to the new intervention, unless the study explicitly estimates the interaction.
Definition. Architecture-family transfer matrix [ftip-00LZ]AGENTDRAFTED
Definition. Architecture-family transfer matrix [ftip-00LZ]AGENTDRAFTED
A transfer matrix records which interfaces, intervention arms, and budgets permit a comparison. Each row is a study record: its source, estimand, matched controls, evaluation coordinates, and declared scope boundary are explicit. A blank or incompatible cell is an incomparability finding, not a missing score to be imputed. The vector and evaluation coordinates are reported together under the conditional frontier of Definition [ftip-00JM].
| Comparison cell | Source | Estimand | Matched controls | Cost / stability / monitorability | Status and scope boundary |
|---|---|---|---|---|---|
| Transformer--KDA/full attention | Remark [ftip-00KF], Definition [ftip-00LU], Example [ftip-00LQ] | Difference in utility, cost, and \(K_{\rm state}\) between KDA and full attention | Same task, model scale, recipe, context, seeds, and evaluation law | Report measured cost vector, training/inference stability, and state/failure observability | Open; a finite KDA--Transformer result does not establish an architecture-wide ceiling |
| Transformer--Mamba | Mamba, Sections 3.1--3.3; § [ftip-00OQ] | Difference in retrieval utility and \(K_{\rm state}\) at the declared budget | Task, scale, recipe, context, and inference budget | Report cost vector, recurrence stability, and state/failure observability | Open; selective compression does not transfer a retrieval result across tasks |
| Transformer--linear attention | Linear attention, Sections 3.2--3.3; § [ftip-00OQ] | Difference in retrieval utility and \(K_{\rm state}\) for associative summaries | Task family, feature map, context budget, and evaluation law | Report prefix cost, numerical stability, and summary-state observability | Open; associative summaries do not imply full-attention equivalence |
| Transformer--CTM or looped model | Continuous Thought Machine, Sections 3.1--3.5; § [ftip-00KG]; § [ftip-00OQ] | Difference in utility and \(K_{\rm adapt}\) per charged tick or loop | Input, base model, stopping rule, recipe, and charged internal compute | Report tick/loop cost, training and inference stability, and stopping-signal monitorability | Open; extra passes are charged and do not imply continuous-time behavior |
| Transformer--BDH | BDH, Section 3.2; § [ftip-00OQ] | Difference in task utility and \(K_{\rm state}\) under the reduced state interface | Task, state parameterization, credit horizon, systems stack, and cost | Report memory and compute cost, optimization stability, and state observability | Open; a reduced state-space proposal is not a production transfer result |
| Transformer-Recurrent Looped Transformer | § [ftip-00OQ]; [zhang2026rlt, Sections 2-3 and 5-8] | Paired change in finite-task utility and \(K_{\rm state}\) under recurrent decoder feedback | Same task, model family, parameter count, training tokens, seeds, and feedback interface; causal no-feedback and chunking arms | Report encoder/decoder FLOPs, recurrent state, chunk latency, memory, stability, and state monitorability | Open and finite-only until a declared deployment arm and transfer record exist |
| Residual baseline: Deep Delta rewrite | § [ftip-00OQ]; [zhang2026deepdelta, Sections 2-4 and 6] | Paired change in utility and rewrite-sensitive state behavior after the rank-one read/compare/target/write intervention | Matched residual capacity, optimizer, tokens, seeds, and model family; no-write, write-only, and capacity controls | Report inference FLOPs, memory, residual/cache state, numerical stability, and rewrite monitorability | Open; finite GPT-2 evidence does not establish a general capability or frontier claim |
| Core architecture--JEPA adjunct | I-JEPA, Section 3; § [ftip-00OQ] | Conditional change in \(K_{\rm repr}\) and \(K_{\rm plast}\) after the objective intervention | Same base artifact, target task, predictor budget, data, and optimizer arm | Report intervention cost, training stability, and representation/probe monitorability | Conditional; an objective intervention is not a replacement architecture |
| I-JEPA--SplitJEPA | SplitJEPA, Sections 3.1--3.4; § [ftip-00OQ] | Subspace identifiability and conditional change in \(K_{\rm repr}\) | Matched invariant correspondences, variant-rank premise, normalization, and encoder budget | Report probe cost, numerical and optimization stability, and subspace monitorability | Conditional; identifiability does not become a general I-JEPA guarantee |
| Core architecture--liquid dynamics | Liquid time-constant networks, Sections 1--2; § [ftip-00OQ] | Difference in utility and \(K_{\rm adapt}\) under the solver intervention | Input law, solver, step budget, tolerance, task, and cost vector | Report solver cost, numerical stability, and trajectory/failure monitorability | Open; continuous dynamics and solver choices remain intervention coordinates |
| Core architecture--Neural Operator | Neural Operators, Section 3; § [ftip-00OQ] | Difference in utility and \(K_{\rm repr}\) across discretizations | Function-space task, discretization family, operator layer, and evaluation law | Report training/inference cost, discretization stability, and field-observation monitorability | Open; discretization invariance under one source formulation is not task transfer |
A completed row must report its paired observations through § [ftip-00L4] and the common-recipe, equal-tuning, and restricted-envelope arms of § [ftip-00JU]. Until those records are supplied, its status remains open or incompatible.
Remark. Applying a finite model to an architecture [ftip-00M0]AGENTDRAFTED
Remark. Applying a finite model to an architecture [ftip-00M0]AGENTDRAFTED
A toy representation or recurrence result may motivate a hypothesis, but it is not transferred to a model instance until its interface, task, cost accounting, numerical regime, and evaluation protocol are instantiated and checked. If any required assumption is unverified, applicability to the model instance remains unestablished.
Definition. Negative-result and stopping report [ftip-00M1]AGENTDRAFTED
Definition. Negative-result and stopping report [ftip-00M1]AGENTDRAFTED
A completed comparison reports the tested cost grid, excluded configurations, stopping rule, uncertainty, and negative results. Stopping without a detected difference is evidence about the declared study, not proof that the architectures have equal potential.
Remark. Open comparison questions [ftip-00M2]AGENTDRAFTED
Remark. Open comparison questions [ftip-00M2]AGENTDRAFTED
The matrix in Definition [ftip-00LZ] is a protocol map, not a result table. The following probes keep the five capability coordinates separate and leave an unknown cell visible until the required records exist. Each probe names its source, estimand, controls, and evaluation coordinates so that a missing record cannot be mistaken for a zero score.
- State access. Sources: Mamba, Sections 3.1--3.3 and linear attention, Sections 3.2--3.3. Estimand: the paired difference in retrieval utility and \(K_{\rm state}\). Controls: Transformer, Mamba, and linear-attention systems on a predeclared retrieval and continuation suite at matched parameter, context, recipe, and cost budgets. Evaluation: report cost, recurrence or summary stability, and state observability. Scope boundary: a long-context score does not transfer to another task family without its task and transport record.
- Recurrent feedback. Source: [zhang2026rlt, Sections 2-3 and 5-8]. Estimand: the paired change in finite-task utility and \(K_{\rm state}\) from decoder feedback. Controls: a common causal encoder, model size, training tokens, seeds, and matched per-token budget, with no-feedback and declared chunk-size arms. Evaluation: report recurrent-state bytes, encoder/decoder FLOPs, chunk latency, numerical/training stability, and feedback monitorability. Scope boundary: parity, permutation tracking, and modular arithmetic remain finite evidence; without a deployment and transfer record, the cell is finite-only.
- Residual rewrite. Source: [zhang2026deepdelta, Sections 2-4 and 6]. Estimand: the paired change in utility and rewrite-sensitive state behavior from a gated rank-one read/compare/target/write edit. Controls: residual capacity, optimizer, tokens, seeds, and model family, with no-write, write-only, and capacity-matched arms. Evaluation: report rewrite and residual-state monitorability, inference FLOPs, memory, numerical stability, and a held-out transfer task. Scope boundary: finite GPT-2 observations do not identify a general capability gain or architecture-wide law.
- Adaptive computation. Source: Continuous Thought Machine, Sections 3.1--3.5 and the looped-model contract in § [ftip-00KG]. Estimand: the paired change in utility and \(K_{\rm adapt}\) per charged internal tick or loop. Controls: common input, base model, recipe, stopping rule, and charged internal compute. Evaluation: report tick/loop cost, training and inference stability, and stopping-signal monitorability. Scope boundary: an observed adaptive gain remains conditional on that stopping law.
- Representation and abstraction. Sources: I-JEPA, Section 3 and SplitJEPA, Sections 3.1--3.4. Estimand: subspace identifiability and the conditional change in \(K_{\rm repr}\). Controls: fixed correspondences, full-rank variant differences, normalization, encoder budget, and matched downstream probes. Evaluation: report probe cost, optimization stability, and subspace monitorability. Scope boundary: the conditional subspace result is separate from downstream task transfer; failure of a premise is an incompatible cell, not a zero score.
- Plasticity. Source: the objective and optimizer interfaces in Definition [ftip-00JM] and the I-JEPA intervention description in § [ftip-00OQ]. Estimand: the paired change in \(K_{\rm plast}\) after a declared post-training intervention. Controls: common recipe and equal-tuning arms with data, optimizer, trial count, stopping, and feedback fixed or explicitly varied. Evaluation: report intervention cost, training stability, and update-signal monitorability. Scope boundary: an intervention effect is limited to the declared base artifact, task, and objective; it does not transfer across architectures without a new paired record.
- Portability. Sources: the Mamba, BDH, and Neural Operator method descriptions in § [ftip-00OQ]: Mamba, BDH, and Neural Operators. Estimand: survival of the declared utility and \(K_{\rm port}\) across one transfer edge. Controls: source model, task family, model scale, deployment regime, evaluation law, and cost vector retained as paired fields. Evaluation: report migration cost, stability after the shift, and failure monitorability. Scope boundary: evidence for one transfer edge does not order unmeasured edges; blank edges remain unmeasured.
- Adjunct interactions. Sources: liquid time-constant networks, Sections 1--2, Neural Operators, Section 3, and I-JEPA, Section 3. Estimand: the joint change in the declared capability coordinates after an explicit intervention. Controls: declared core model, objective, temporal law, function-space bias, matched controls, and separate single-intervention arms. Evaluation: report joint and marginal costs, numerical/training stability, and interaction monitorability. Scope boundary: a joint effect is limited to the declared core, task, temporal law, and function-space regime; it does not transfer across regimes without separate intervention records.
Semantic representation diagnostics along pretraining checkpoints [ftip-00OZ]AGENTDRAFTED
Semantic representation diagnostics along pretraining checkpoints [ftip-00OZ]AGENTDRAFTED
This bounded diagnostic records when a declared semantic representation becomes recoverable along a pretraining trajectory. It uses the spatial and temporal probing design of [gurnee2024space, Sections 2-4 and 7] as a measurement template. The result is a representation diagnostic, not a claim about a developmental mechanism, a deployment capability, or a post-training law.
The task family is fixed before inspecting checkpoints: the six coordinate task datasets in the source family (world, United States, and New York City locations; historical figures, cultural works, and news headlines). Each score uses held-out entities. An eligible model family supplies at least three ordered pretraining checkpoints, identical train, validation, and test entity splits and filtering at every checkpoint, and the same layer-wise linear ridge-probe protocol, including a predeclared ridge-regularization grid and validation selection rule. A family or checkpoint missing one of those fields is reported as missing rather than silently pooled.
For model family \(m\), checkpoint \(c\), task \(q\), and layer \(\ell \), let \(s^{\mathrm {val}}_{m,c,q,\ell }\) and \(s^{\mathrm {test}}_{m,c,q,\ell }\) be validation and held-out-test coefficients of determination for the fixed probe. Choose the layer on validation entities, then evaluate once on the test entities:
\[ \ell ^*_{m,c,q}=\arg \max _{\ell \in L_m}s^{\mathrm {val}}_{m,c,q,\ell },\qquad s_{m,c,q}=s^{\mathrm {test}}_{m,c,q,\ell ^*_{m,c,q}}. \]A predeclared layer may replace the validation choice, but a test score is never used to select \(\ell ^*\); this keeps the emergence score from being a layer-selection envelope.
The primary absolute emergence threshold is \(\tau =0.50\) in this held-out score, chosen before the trajectory is inspected. The first crossing is
\[ e_{m,q}(\tau )=\min \{c:s_{m,c,q}\geq \tau \}, \]with \(e_{m,q}(\tau )=\bot \) when no checkpoint crosses. A crossing is reported with the checkpoint token count, layer, a bootstrap uncertainty interval over held-out entities, and the probe seed; it is not smoothed into a claim about an unobserved training interval. Sensitivity must include \(\tau \in \{0.25,0.50,0.75\}\), model family, parameter scale, and checkpoint spacing.
The structural record contains held-out coordinate prediction, block and cross-entity generalization, prompt variants, and the layer at which the score peaks. These are content and representation probes. A function or deployment record is separate: it must specify an intervention or user task, an outcome metric, matched controls, and its own cost and failure accounting. A probe crossing alone cannot populate that record.
The source reports linear spatial and temporal representations across Llama-2 and Pythia scales, prompt sensitivity, cross-entity robustness, and individual neurons; see [gurnee2024space, Sections 2.1-2.3, 3.1-3.3, 4.1-4.2, and 5]. Those observations motivate the fields above, but every trajectory association reported by this protocol is noncausal. In particular, it makes no claim about which training environment caused the score, whether a representation is used by a deployed function, or what post-training will preserve.
Each trajectory record therefore retains the model family and size, checkpoint token count, task and entity split, probe class and seed, all layer scores, threshold grid, missingness, and the separately reported function or deployment assay. Comparisons are within the declared task family and model family before any cross-family summary. A change in checkpoint spacing or probe protocol is a new arm, not evidence of an earlier or later emergence.
Convention. Identifiability regimes for semantic representation diagnostics [ftip-00P1]AGENTDRAFTED
Convention. Identifiability regimes for semantic representation diagnostics [ftip-00P1]AGENTDRAFTED
Zhou and Klindt study labels-to-latents and latents-to-labels data-generating directions. Their general assumptions include a fixed continuous invertible map \(g:Z\to X\), a continuous learned encoder with \(h=f\mathbin \circ g\), a row-centered log-linear posterior \(p(y|z)={\rm softmax}(W^*z)\), effective dimension \(n'={\rm rank}(W^*)\), and a global population cross-entropy optimum with linear readout \(U\). The source boundary for this note is the DGP construction and assumptions in Sections 3.1 to 3.2, Theorems 4.1 to 4.4, Sections 5.1 to 5.4, and Section 6, with Supplementary Assumptions 8.1 to 8.3, of [zhou2026complete, Theorems 4.1 to 4.4, Sections 3 to 5, and Section 6].
Source observation. When \(m\geq n'\), Theorem 4.1 makes the classification-relevant part of every optimum linear, \(h(z)=Az+\nu (z)\) with \(UA=W^*\); the null-readout term satisfies \(\nu (z)\in N(U)\) and may remain unconstrained. When \(m<n'\), Theorem 4.2 gives generic nonlinear, non-identifiable optima when \(\operatorname {supp}(p_Z)\) has nonempty interior \(\Omega \), \(p_Z\) is continuous and strictly positive on \(\Omega \), and every candidate \(A\) has \(N(A)\cap \Omega \ne \varnothing \). These are different capacity regimes, not two scores for one representation.
The stronger conclusions require additional structure. In the generative case, Assumption 8.2 takes \(Z=\mathbb R_+^n\) and adds a factorized exponential conditional, constant conditional entropy, a uniform class prior, exact capacity \(m=n=n'\), non-negative activations, fixed within-class variance, and an energy-minimizing global optimum. Theorem 4.3 then gives the scaled permutation \(h(z)=DP_\sigma z\). In the discriminative case, Assumption 8.3 uses \(A^*\in \mathbb R^{n\prime \times n}\) with full row rank and \(U^*\in \mathbb R^{|Y|\times n\prime }\), adds \(W^*=U^*A^*\), \(k\)-sparse latents, and \(\operatorname {spark}(A^*)>2k\). With \(m\geq n\prime \), let \(P_U\) be the orthogonal projector onto \(\operatorname {Row}(U)\); the classifier-visible encoder \(P_Uh(z)=Az\) has \(N(A)=N(A^*)\), so the unique \(k\)-sparse solution can recover \(z\). Axis alignment and sparse recovery are distinct routes through distinct assumptions.
Section 5 reports finite experiments rather than a universal law. Linear alignment uses held-out coefficient of determination for a linear decoder; axis alignment uses the mean correlation coefficient (MCC) after Hungarian matching recovered axes to true latents. Sparse recovery compares supervised Lasso, dense OLS, and unsupervised sparse dictionary learning. Cross-system correspondence uses the Maximum Matching Unit (MMU): for each source unit, the maximum absolute Pearson correlation with any unit in a declared comparison model and layer on a declared stimulus set. The synthetic experiments use ten random seeds; the real-data cross-system analysis does not inherit that seed count. Section 6 records limits from constant conditional entropy, non-negativity, class priors, and the assumed sparse data-generating process; signed latents do not inherit Theorem 4.3 directly.
Finite identifiability record. For a fixed model family, checkpoint, task split, and probe seed, record
\[ \mathcal D=\bigl (r,m,n,n',\mathcal A,[h]_{\sim _r},R^2_{\rm lin}, R^2_{\rm sparse},\operatorname {MCC}_{\rm axis}, \operatorname {MCC}_{\rm sparse},\operatorname {MMU}_{\rm cross},\mathsf E\bigr ). \]Here \(r\) is one declared regime: sufficient-capacity linear, undercomplete nonlinear, generative axis-aligned, or discriminative sparse recovery. \(\mathcal A\) lists the causal direction, DGP, capacity, sparsity, and assumptions actually held. \(R^2_{\rm lin}\) is the held-out coefficient for linear latent alignment; \(R^2_{\rm sparse}\) names the decoder and target, with supervised Lasso and dense OLS kept as separate arms. \(\operatorname {MCC}_{\rm axis}\) records the matching and correlation convention for axis recovery, while \(\operatorname {MCC}_{\rm sparse}\) records the matching convention, sparsity level, and whether the decoder is supervised or an unsupervised dictionary. \(\operatorname {MMU}_{\rm cross}\) records the directed source and comparison model, layers, unit sets, stimulus set, and correlation rule. An unavailable or inapplicable field is \(\bot \).
The equivalence class identifies only the ambiguity allowed by the declared regime: \((A,\nu )\) with \(UA=W^*\), \(\operatorname {rank}(A)=n'\), and \(\nu (z)\in N(U)\) in the linear regime; no universal quotient, recorded as non-identifiable under the stated assumptions, in the undercomplete regime; positive diagonal scaling and permutation \((D,P_\sigma )\) in the axis-aligned regime; and the classifier-visible null-space class \(N(A)=N(A^*)\) in the sparse regime. A sparse decoder has permutation-and-scaling ambiguity only when that convention is declared and measured. No scalar summary is defined, and none of these fields alone establishes monosemanticity.
Source-grounded finite instance. In the compressed-sensing arm, the paper fixes \(n=16\), \(n'=m=8\), \(|Y|=64\), draws a Gaussian measurement matrix with normalized columns, and tests \(k\in \{1,2,3\}\) over ten seeds. For the \(k=1\) arm, the record declares discriminative sparse recovery and the \(W^*=U^*A^*\) and spark conditions; it reports \(R^2_{\rm sparse}\approx 1\) for supervised Lasso, \(R^2_{\rm sparse}\approx n'/n=0.5\) for OLS, and \(\operatorname {MCC}_{\rm sparse}\approx 0.86\) for unsupervised Lasso, with \(\operatorname {MCC}_{\rm axis}=\bot \) and \(\operatorname {MMU}_{\rm cross}=\bot \). The ten-seed estimate, decoder arm, and missing fields are part of \(\mathsf E\); the values are finite synthetic observations, not a deployment or capability claim.
FTIP deduction. This record makes the representation question conditional on capacity, causal direction, and an explicit equivalence class. It lets the existing checkpoint route report linear recoverability, axis alignment, sparse recovery, and cross-system matching without treating any one readout as a capability or deployment result. A finite observation can support a regime-specific comparison; it cannot identify a developmental mechanism or transfer beyond the declared task and assumptions.
Proposed protocol. Before inspecting a checkpoint, freeze the task family, latent or proxy labels, split, width ratio, causal regime, assumptions, decoder class, comparison model and layer for MMU, stimulus set, and held-out evaluator. Select layers or decoder settings on validation data only. Report the full record, seed repetitions, missingness, and assumption-violation arms; keep each \(R^2\), MCC, and MMU in its native units. For real model activations, treat latent recovery as a declared proxy assay and report the proxy construction with the same boundary.
A scoped local formalization search of Forest, formal-math, TauCetiReview, and TauCetiWorker found no declaration that packages this four-regime record with its separately typed readouts. Existing representation and evaluation declarations cover neighboring fields only, so this finite identifiability record remains a protocol proposal.
This protocol links the conceptual-discovery question in § [ftip-00MH] to the capability coordinates in Definition [ftip-00JM]; the panel of open comparison questions in Remark [ftip-00M2] transcludes this child.
These probes do not establish a common ordering of architecture families. They specify what would count as evidence for a declared bottleneck change, while cost, numerical stability, monitorability, and transfer remain separate evaluation coordinates. Paired observations should use § [ftip-00L4], the study arms of § [ftip-00LS], and the capability vector of Definition [ftip-00JM]. Recurrent feedback and residual rewrite remain separate arms in every record; a finite result without a deployment arm stays finite-only.
Optimizer geometry and representation dependence [ftip-00AU]AGENTDRAFTED
Optimizer geometry and representation dependence [ftip-00AU]AGENTDRAFTED
A scalar objective does not by itself determine a training intervention. This section studies an exact finite-dimensional witness: one represented matrix can have many factor bases, the loss can be constant along that gauge orbit, and an update rule can nevertheless distinguish the bases.
The principal source is the version-one arXiv preprint The loss does not see the basis, but Adam does[singh2026lossbasis]. Its algebraic results assume the stated dimensions, rank conditions, state conventions, and real arithmetic. Experimental observations concern the reported configurations.
Factored objectives and gauge symmetry [ftip-00AV]AGENTDRAFTED
Factored objectives and gauge symmetry [ftip-00AV]AGENTDRAFTED
We first separate a represented matrix from a choice of factors and then separate its full product-preserving symmetry from the orthogonal subgroup that preserves the Euclidean parameter metric.
Notation. Factored objective and represented matrix [ftip-00AW]AGENTDRAFTED
Notation. Factored objective and represented matrix [ftip-00AW]AGENTDRAFTED
Fix integers \(d_1,d_2,k\geq 1\). Let \(U\in \mathbb R^{d_1\times k}\) and \(V\in \mathbb R^{d_2\times k}\) be factors, let
\[ W(U,V)=UV^{\mathsf T}\in \mathbb R^{d_1\times d_2}, \]and let \(f:\mathbb R^{d_1\times d_2}\to \mathbb R\) be differentiable. The corresponding factored objective is \(L(U,V)=f(W(U,V))\). The pair \((U,V)\) is a parameterization; \(W(U,V)\) is the represented object on which \(f\) depends. This is the rectangular form noted in Section 3 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Definition. General linear gauge action [ftip-00AX]AGENTDRAFTED
Definition. General linear gauge action [ftip-00AX]AGENTDRAFTED
For \(A\in \mathrm {GL}(k)\), define the general linear gauge action by
\[ \gamma _A(U,V)=(UA,VA^{-\mathsf T}). \]The inverse transpose on the second factor is essential for a general invertible \(A\). When \(A=Q\in \mathrm O(k)\), one has \(Q^{-\mathsf T}=Q\), and the action becomes \((UQ,VQ)\).
Lemma. The gauge action preserves the product and loss [ftip-00AY]AGENTDRAFTED
Lemma. The gauge action preserves the product and loss [ftip-00AY]AGENTDRAFTED
For every \(A\in \mathrm {GL}(k)\),
\[ W(UA,VA^{-\mathsf T})=UV^{\mathsf T} \quad \hbox {and}\quad L(UA,VA^{-\mathsf T})=L(U,V). \]
Proof.
Proof.
Since \((VA^{-\mathsf T})^{\mathsf T}=A^{-1}V^{\mathsf T}\), the first identity is \(UAA^{-1}V^{\mathsf T}=UV^{\mathsf T}\). Applying \(f\) gives the second.
This is the factored-model calculation in Section 3 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Definition. Orthogonal gauge orbit [ftip-00AZ]AGENTDRAFTED
Definition. Orthogonal gauge orbit [ftip-00AZ]AGENTDRAFTED
The orthogonal gauge orbit of \((U,V)\) is
\[ \mathcal O(U,V)=\{(UQ,VQ):Q\in \mathrm O(k)\}. \]Every pair in the orbit represents the same \(W\). This orbit is generally smaller than the complete fibre of the map \((U,V)\mapsto UV^{\mathsf T}\). The restriction to \(\mathrm O(k)\) is geometric: it preserves the Euclidean metric on factor space.
Lemma. The orthogonal gauge is the maximal isometric subgroup [ftip-00B0]AGENTDRAFTED
Lemma. The orthogonal gauge is the maximal isometric subgroup [ftip-00B0]AGENTDRAFTED
The action \(\gamma _A\) preserves \(\lVert U\rVert _F^2+\lVert V\rVert _F^2\) for every pair \((U,V)\) if and only if \(A\in \mathrm O(k)\).
Proof.
Proof.
If the action is an isometry, take \(V=0\) and let one row of \(U\) be an arbitrary \(u\in \mathbb R^{1\times k}\). Then \(\lVert uA\rVert _2=\lVert u\rVert _2\) for every \(u\), hence \(AA^{\mathsf T}=I\). Conversely, right multiplication by an orthogonal matrix preserves both Frobenius norms.
See Lemma 3.2 and its proof in Appendix B.1 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Lemma. Gradients transform covariantly along an orthogonal orbit [ftip-00B1]AGENTDRAFTED
Lemma. Gradients transform covariantly along an orthogonal orbit [ftip-00B1]AGENTDRAFTED
For \(Q\in \mathrm O(k)\),
\[ \nabla _U L(UQ,VQ)=\nabla _U L(U,V)Q, \qquad \nabla _V L(UQ,VQ)=\nabla _V L(U,V)Q. \]
Proof.
Proof.
Put \(G=\nabla f(W)\). Then \(\nabla _U L=GV\) and \(\nabla _V L=G^{\mathsf T}U\). The represented matrix, and hence \(G\), is unchanged along the orbit. Substitution gives both identities.
See Lemma 4.1 and its proof in Appendix B.2 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Definition. Optimizer state action [ftip-00B2]AGENTDRAFTED
Definition. Optimizer state action [ftip-00B2]AGENTDRAFTED
Use the optimizer-state convention of Definition [ftip-001H]. For every \(Q\in \mathrm O(k)\), an optimizer state action is a map \(\sigma _Q:\mathcal S_{\rm opt}\to \mathcal S_{\rm opt}\) compatible with the shapes of the factor states and satisfying \(\sigma _Q(s_0)=s_0\) for the declared initial state.
For example, a momentum buffer shaped like \(U\) transforms by right multiplication by \(Q\); a shared scalar second moment is fixed. An entrywise second-moment array need not admit a state action compatible with every orthogonal \(Q\).
Definition. Gauge-equivariant optimizer [ftip-00B3]AGENTDRAFTED
Definition. Gauge-equivariant optimizer [ftip-00B3]AGENTDRAFTED
Let \(\mathcal A\) be a deterministic instance of the parameter-update rule of Definition [ftip-001I], acting on \((U,V,s)\). It is gauge-equivariant when for every \(Q\in \mathrm O(k)\) there is a state action \(\sigma _Q\) such that gauge-related initial states produce
\[ (\widetilde U_t,\widetilde V_t,\widetilde s_t) =(U_tQ,V_tQ,\sigma _Q(s_t)) \qquad (t\geq 0). \]This is Definition 3.1 of The loss does not see the basis, but Adam does[singh2026lossbasis]. Any randomness, schedules, stopping rule, and mixed update blocks must also be coupled as required by Remark [ftip-001J]; the definition does not hide them.
Example. A commuting optimizer square [ftip-00B4]AGENTDRAFTED
Example. A commuting optimizer square [ftip-00B4]AGENTDRAFTED
One update of a gauge-equivariant optimizer makes the following square commute. The vertical arrows change factor basis and the horizontal arrows apply the same declared update.
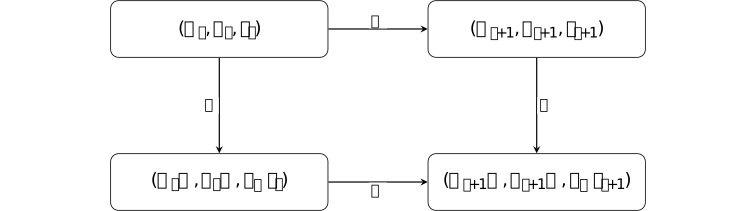
Commutation is stronger than equality of the scalar losses before the step. It states equality of the represented product trajectory after aligning the parameter bases.
Remark. Product symmetry is larger than the isometric gauge [ftip-00B5]AGENTDRAFTED
Remark. Product symmetry is larger than the isometric gauge [ftip-00B5]AGENTDRAFTED
The full \(\mathrm {GL}(k)\) action in Definition [ftip-00AX] preserves \(W\), but ordinary Euclidean gradients are covariant under the orthogonal specialization used in Lemma [ftip-00B1]. A theorem for \((UQ,VQ)\) must therefore not be silently promoted to every product-preserving reparameterization.
The source calls the orthogonal subgroup the gauge in its optimizer classification while also noting the larger function-preserving group. These are compatible statements only when their different geometric scopes remain explicit.
Equivariant and basis-sensitive update rules [ftip-00B6]AGENTDRAFTED
Equivariant and basis-sensitive update rules [ftip-00B6]AGENTDRAFTED
Gradient covariance supplies a test for update rules. Linear and full-matrix operations can commute with a latent rotation, whereas a fixed nonlinear map applied separately to coordinates selects a preferred basis.
Definition. Memoryless right-equivariant update [ftip-00B7]AGENTDRAFTED
Definition. Memoryless right-equivariant update [ftip-00B7]AGENTDRAFTED
A memoryless factor-update map is a function \(\Phi :\mathbb R^{n\times k}\to \mathbb R^{n\times k}\) applied to a current gradient \(G\) without a persistent optimizer state. It is right-equivariant when
\[ \Phi (GQ)=\Phi (G)Q \qquad (G\in \mathbb R^{n\times k},\ Q\in \mathrm O(k)). \]This local definition is the input of Theorem 4.5 in The loss does not see the basis, but Adam does[singh2026lossbasis]. It does not classify stateful optimizers such as Adam.
Proposition. Gradient descent and momentum preserve the orthogonal gauge [ftip-00B8]AGENTDRAFTED
Proposition. Gradient descent and momentum preserve the orthogonal gauge [ftip-00B8]AGENTDRAFTED
Gradient descent and Polyak or Nesterov momentum are gauge-equivariant when their factor gradients, momentum buffers, schedules, and look-ahead points are transformed consistently.
Proof.
Proof.
By Lemma [ftip-00B1], \(G_t\) becomes \(G_tQ\). Gradient descent therefore sends \(U_tQ\) to \((U_t-\eta _tG_t)Q\). A momentum buffer initialized at zero and formed by linear combinations of covariant gradients transforms as \(M_tQ\); a Nesterov look-ahead point is likewise the reference look-ahead right-multiplied by \(Q\). Induction proves the claim.
Proposition 4.2(1) and its proof are in Appendix B.3 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Proposition. A shared scalar second moment preserves the orthogonal gauge [ftip-00B9]AGENTDRAFTED
Proposition. A shared scalar second moment preserves the orthogonal gauge [ftip-00B9]AGENTDRAFTED
Replace Adam's entrywise second-moment denominator by one scalar whose updates depend only on gauge-invariant quantities such as the pooled mean of the squared entries of both factor gradients. With a covariant first-moment buffer, the resulting stateful update is gauge-equivariant.
Proof.
Proof.
The first moment is a linear exponential average and transforms by right multiplication by \(Q\). The pooled squared-entry mean is the joint squared Frobenius norm divided by the entry count, hence is unchanged by \(G\mapsto GQ\). Its bias correction and positive scalar denominator are unchanged, so the complete update transforms covariantly.
Proposition 4.2(2) and its proof are in Appendix B.3 of The loss does not see the basis, but Adam does[singh2026lossbasis]. The result concerns this declared shared-scalar variant, not stock Adam.
Proposition. Full-matrix Muon and Shampoo preserve the orthogonal gauge [ftip-00BA]AGENTDRAFTED
Proposition. Full-matrix Muon and Shampoo preserve the orthogonal gauge [ftip-00BA]AGENTDRAFTED
Fix one factor, write \(n\in \{d_1,d_2\}\) for its row dimension, and let \(G_t,M_t\in \mathbb R^{n\times k}\) be its gradient and Muon momentum buffer. For \(0\leq \beta <1\), \(M_{-1}=0\), and the source's linear momentum update \(M_t=\beta M_{t-1}+G_t\), Muon's direction is \(\Delta _t=\operatorname {msign}(M_t)\). Under real arithmetic this stateful update and the source's damped Shampoo update are right-equivariant. The Muon claim includes the stated finite Newton--Schulz approximations; the Shampoo claim uses its complete left and right accumulators.
Proof.
Proof.
By Lemma [ftip-00B1], the primed gradient is \(G'_t=G_tQ\). Starting from \(M'_{-1}=M_{-1}Q=0\), induction through the linear momentum update gives \(M'_t=M_tQ\). If \(M_t=A\Sigma B^{\mathsf T}\) is a compact singular-value decomposition, then \(M_tQ=A\Sigma (Q^{\mathsf T}B)^{\mathsf T}\), so \(\operatorname {msign}(M_tQ)=\operatorname {msign}(M_t)Q\). For \(\epsilon _{\rm NS}>0\), the Newton--Schulz initialization \(X_0=M_t/(\lVert M_t\rVert _F+\epsilon _{\rm NS})\) is covariant because its Frobenius normalization is invariant; each polynomial iterate formed from \(X_j\) and \(X_jX_j^{\mathsf T}\) preserves the same covariance. For Shampoo, the left accumulator is invariant while the right accumulator transforms by \(R_t\mapsto Q^{\mathsf T} R_t Q\). Orthogonal functional calculus conjugates the right matrix function, so the transformed update is the original update right-multiplied by \(Q\).
Proposition 4.2(3)--(4) and its proof are in Appendix B.3 of The loss does not see the basis, but Adam does[singh2026lossbasis]. Variable splitting, coordinatewise clipping, mixed update rules, finite precision, and different damping conventions lie outside this statement. The Muon part is stateful; it does not replace the momentum buffer by the current gradient or invoke the memoryless classification of Definition [ftip-00B7].
Proposition. Coordinatewise equivariance forces linearity [ftip-00BB]AGENTDRAFTED
Proposition. Coordinatewise equivariance forces linearity [ftip-00BB]AGENTDRAFTED
Let \(k\geq 2\) and let a memoryless update have the fixed entrywise form \(\Phi (G)_{ij}=\phi (G_{ij})\). If \(\Phi (GQ)=\Phi (G)Q\) for every \(G\) and \(Q\in \mathrm O(k)\), then \(\phi (x)=cx\) for some \(c\in \mathbb R\).
Proof.
Proof.
It suffices to use one row and rotations in the first two coordinates. Equivariance at zero gives \(\phi (0)=0\). Rotating \((x,0)\) through an angle whose cosine is \(a\in [-1,1]\) gives \(\phi (ax)=a\phi (x)\). For nonzero \(x,y\), compare each with a third number of at least their absolute magnitudes; the ratio \(\phi (x)/x\) is constant.
Proposition 4.3 and its proof are in Appendix B.4 of The loss does not see the basis, but Adam does[singh2026lossbasis]. No continuity assumption is needed.
Corollary. Fixed nonlinear coordinatewise updates break the gauge [ftip-00BC]AGENTDRAFTED
Corollary. Fixed nonlinear coordinatewise updates break the gauge [ftip-00BC]AGENTDRAFTED
A nonlinear fixed entrywise update applied at a zero optimizer state is not gauge-equivariant when \(k\geq 2\). In particular, the source applies Proposition [ftip-00BB] to the first-step maps of Adam, RMSProp, signSGD, and Lion; it checks Adafactor separately because its factored statistics are not an entrywise map.
This is a first-step obstruction. It suffices to disprove equivariance of the full run, but it does not classify every later state or say that such an optimizer cannot reach a particular solution.
Definition. First-step Adam map and gauge defect [ftip-00BD]AGENTDRAFTED
Definition. First-step Adam map and gauge defect [ftip-00BD]AGENTDRAFTED
Fix \(\epsilon >0\). For zero-state, bias-corrected Adam define the entrywise first-step direction
\[ D_\epsilon (G)=G\mathbin {\oslash }(|G|+\epsilon ) \]and, for \(Q\in \mathrm O(k)\), define its gauge-aligned defect by
\[ E_Q(G)=D_\epsilon (GQ)Q^{\mathsf T}-D_\epsilon (G). \]Here \(|G|\), addition, and division are entrywise. Bias correction makes the first direction independent of Adam's two decay coefficients under the declared convention [singh2026lossbasis, Proposition 4.4].
Proposition. Exact represented-matrix defect after one Adam step [ftip-00BE]AGENTDRAFTED
Proposition. Exact represented-matrix defect after one Adam step [ftip-00BE]AGENTDRAFTED
Let \(G_U=\nabla _UL(U_0,V_0)\), \(G_V=\nabla _VL(U_0,V_0)\), \(D_U=D_\epsilon (G_U)\), and \(D_V=D_\epsilon (G_V)\). Let \(W_1\) be the product after one Adam step from \((U_0,V_0)\) and \(\widetilde W_1\) the product after one step from \((U_0Q,V_0Q)\). Then
\[ \begin {aligned} \widetilde W_1-W_1={}&-\eta \bigl (E_Q(G_U)V_0^{\mathsf T} +U_0E_Q(G_V)^{\mathsf T}\bigr )\\ &+\eta ^2\bigl (E_Q(G_U)D_V^{\mathsf T} +D_UE_Q(G_V)^{\mathsf T} +E_Q(G_U)E_Q(G_V)^{\mathsf T}\bigr ). \end {aligned} \]
Proof.
Proof.
Gauge-align the rotated factors back by \(Q^{\mathsf T}\). They are \(U_0-\eta (D_U+E_Q(G_U))\) and \(V_0-\eta (D_V+E_Q(G_V))\). Multiply, subtract \((U_0-\eta D_U)(V_0-\eta D_V)^{\mathsf T}\), and collect powers of \(\eta \).
Proposition 4.4 and its proof are in Appendix B.5 of The loss does not see the basis, but Adam does[singh2026lossbasis].
Example. A two-coordinate Adam defect witness [ftip-00BF]AGENTDRAFTED
Example. A two-coordinate Adam defect witness [ftip-00BF]AGENTDRAFTED
Take \(d_1=d_2=1\), \(k=2\), \(f(w)=w^2/2\), \(U_0=V_0=(1,0)\), and
\[ Q=2^{-1/2}\begin {pmatrix}1&1\\-1&1\end {pmatrix}. \]The original and rotated products after one zero-state Adam step are
\[ W_1=\left (1-\frac {\eta }{1+\epsilon }\right )^2, \qquad \widetilde W_1=\left (1-\frac {\eta }{2^{-1/2}+\epsilon }\right )^2. \]
They differ when \(0<\eta <2^{-1/2}+\epsilon \). This is the explicit witness in Proposition 4.4 of The loss does not see the basis, but Adam does[singh2026lossbasis]; it is a statement about one factored quadratic, not about language-model performance.
Example. A rotated sign update fails to commute [ftip-00BG]AGENTDRAFTED
Example. A rotated sign update fails to commute [ftip-00BG]AGENTDRAFTED
For \(G=(1,1)\) and the 45-degree rotation matrix \(Q\) of Example [ftip-00BF], one has \(GQ=(0,\sqrt 2)\). With \(\operatorname {sign}(0)=0\),
\[ \operatorname {sign}(GQ)=(0,1), \qquad \operatorname {sign}(G)Q=(0,\sqrt 2). \]Thus even this two-coordinate update violates the commuting equation in Definition [ftip-00B7]. The calculation is the explicit Appendix B.4 witness of The loss does not see the basis, but Adam does[singh2026lossbasis].
Theorem. Full-rank memoryless equivariant rules are Gram-determined [ftip-00BH]AGENTDRAFTED
Theorem. Full-rank memoryless equivariant rules are Gram-determined [ftip-00BH]AGENTDRAFTED
Let \(k\leq n\), and let \(\Phi \) be defined on full-column-rank matrices \(G\in \mathbb R^{n\times k}\). Then \(\Phi (GQ)=\Phi (G)Q\) for every \(Q\in \mathrm O(k)\) if and only if there is a matrix-valued function \(H\) of \(GG^{\mathsf T}\) such that
\[ \Phi (G)=H(GG^{\mathsf T})G. \]
Proof.
Proof.
The displayed form is immediately equivariant. Let \(G^+\) denote the Moore--Penrose pseudoinverse. Conversely, set \(X(G)=\Phi (G)G^+\). Then \(X(G)G=\Phi (G)\) and \(X(GQ)=X(G)\). Two full-column-rank matrices with the same left Gram matrix have the same range and differ by a right orthogonal factor. Hence \(X(G)\) depends only on \(GG^{\mathsf T}\); take \(H=X\).
See Theorem 4.5 and its proof in Appendix B.6 of The loss does not see the basis, but Adam does[singh2026lossbasis]. It classifies the full-rank stratum only.
Corollary. The square invertible preconditioner representation [ftip-00BI]AGENTDRAFTED
Corollary. The square invertible preconditioner representation [ftip-00BI]AGENTDRAFTED
In the specialization \(k=n\) with \(G\) invertible, let \(P^{1/2}\) denote the unique positive-definite square root of \(P\). The function in Theorem [ftip-00BH] has the unique canonical representative
\[ H(P)=\Phi (P^{1/2})P^{-1/2}, \qquad P=GG^{\mathsf T}>0. \]
Proof.
Proof.
The polar decomposition writes \(G=P^{1/2}Q\). Equivariance gives \(\Phi (G)=\Phi (P^{1/2})Q=H(P)G\). Evaluating at \(G=P^{1/2}\) proves uniqueness in this square invertible case.
For rectangular \(G\), the action of \(H(P)\) away from the range needed to multiply \(G\) is not determined by \(\Phi \). The proof above establishes uniqueness in the square invertible specialization.
Remark. What the structure theorem leaves unresolved at rank deficiency [ftip-00BJ]AGENTDRAFTED
Remark. What the structure theorem leaves unresolved at rank deficiency [ftip-00BJ]AGENTDRAFTED
In the ambient matrix space, full-column-rank matrices form an open dense subset whose complement has Lebesgue measure zero. A probability-one claim requires the random gradient law to be absolutely continuous and not confined to a lower-rank set; random initialization alone does not supply that premise.
Theorem [ftip-00BH] therefore makes no classification claim on a general rank-deficient stratum. Equivariance still constrains values within each orthogonal orbit, and it forces \(\Phi (0)=0\), but it does not determine the rule there by continuity unless continuity is separately assumed. The source's generic-rank discussion therefore does not establish a classification at rank deficiency.
Common-scalar flows, clock changes, and momentum [ftip-00BK]AGENTDRAFTED
Common-scalar flows, clock changes, and momentum [ftip-00BK]AGENTDRAFTED
One narrow class of continuous-time preconditioners follows the gradient-flow path at a different speed. The clock change transfers path properties, but not rates, and it does not encompass a stateful momentum method.
Definition. Common-scalar preconditioned flow [ftip-00BL]AGENTDRAFTED
Definition. Common-scalar preconditioned flow [ftip-00BL]AGENTDRAFTED
Let \(\theta =(U,V)\) and let \(a(t)>0\) be measurable with \(1/a\) locally integrable. A common-scalar preconditioned flow is a locally absolutely continuous trajectory satisfying
\[ \dot \theta (t)=-\frac {\nabla L(\theta (t))}{a(t)} \]for almost every \(t\). The same scalar multiplies every coordinate of both factor gradients. For gauge-uniform conclusions, the source additionally requires \(a(t)\) to be determined by gauge-invariant statistics of the trajectory up to time \(t\).
Definition. Effective optimizer clock [ftip-00BM]AGENTDRAFTED
Definition. Effective optimizer clock [ftip-00BM]AGENTDRAFTED
For the flow of Definition [ftip-00BL], define the effective optimizer clock
\[ \tau (t)=\int _0^t\frac {du}{a(u)}, \qquad \tau _{\max }=\int _0^\infty \frac {du}{a(u)}, \qquad 0<\tau _{\max }\leq \infty . \]The clock is strictly increasing on its domain. If \(\tau _{\max }=\infty \), it reaches every gradient-flow time; otherwise it traverses only the prefix with effective time below \(\tau _{\max }\).
Theorem. Common-scalar flow is a time-reparameterized gradient flow [ftip-00BN]AGENTDRAFTED
Theorem. Common-scalar flow is a time-reparameterized gradient flow [ftip-00BN]AGENTDRAFTED
Let \(\theta (t)\) satisfy Definition [ftip-00BL], let \(t(\tau )\) be the inverse of the clock in Definition [ftip-00BM], and put \(\widetilde \theta (\tau )=\theta (t(\tau ))\). Then, for almost every \(\tau \),
\[ \widetilde \theta '(\tau )=-\nabla L(\widetilde \theta (\tau )). \]
Proof.
Proof.
The chain rule for absolutely continuous changes of variable gives \(dt/d\tau =a(t)\) almost everywhere. Multiplying \(\dot \theta =-\nabla L/a(t)\) by \(dt/d\tau \) yields the displayed gradient flow.
See Theorem 4.6 and its proof in Appendix B.9 of The loss does not see the basis, but Adam does[singh2026lossbasis]. Gauge invariance of \(a\) is not needed for this single-trajectory clock identity; it makes the clock common across a gauge orbit.
Corollary. Transfer of path and limit properties [ftip-00BO]AGENTDRAFTED
Corollary. Transfer of path and limit properties [ftip-00BO]AGENTDRAFTED
Every property depending only on the portion of the gradient-flow path traversed before \(\tau _{\max }\) transfers to the common-scalar flow. If \(\tau _{\max }=\infty \) and gradient flow converges, both flows have the same limit point. A sufficient condition for clock divergence is an eventual finite upper bound on \(a(t)\).
For shallow factorization, the source cites Implicit regularization in matrix factorization[gunasekar2017implicit]. For deep factorization, it cites Implicit regularization in deep matrix factorization[arora2019implicit]. For greedy low-rank dynamics, it cites Towards resolving the implicit bias of gradient descent for matrix factorization: Greedy low-rank learning[li2021greedy].
Those conclusions transfer only when both this clock theorem and every hypothesis of the original result hold. This corollary supplies no missing matrix-sensing assumption.
Remark. Rates and hitting times do not survive time reparameterization [ftip-00BP]AGENTDRAFTED
Remark. Rates and hitting times do not survive time reparameterization [ftip-00BP]AGENTDRAFTED
Two flows can traverse the same curve with arbitrarily different physical clocks. A convergence rate, finite-step budget, or hitting time stated in \(t\) therefore does not transfer through Theorem [ftip-00BN] without quantitative bounds on \(a\) and its integral. If \(\tau _{\max }<\infty \), even the tail and limit of the gradient-flow path are not reached.
Remark. Scalar-Adam is outside the common-scalar flow theorem [ftip-00BQ]AGENTDRAFTED
Remark. Scalar-Adam is outside the common-scalar flow theorem [ftip-00BQ]AGENTDRAFTED
The shared-scalar Adam variant in Proposition [ftip-00B9] retains a first-moment exponential moving average. It is stateful and is not the memoryless flow in Definition [ftip-00BL]. Remark 4.7 of The loss does not see the basis, but Adam does[singh2026lossbasis] treats its agreement with gradient flow as empirical rather than as a consequence of Theorem 4.6.
The theorem likewise does not apply to discrete Adam, PPO, RLVR update loops, clipping, weight decay, and mixed optimizers. Gauge equivariance and time reparameterization are separate properties.
Example. Equivariance neither guarantees nor precludes recovery [ftip-00BR]AGENTDRAFTED
Example. Equivariance neither guarantees nor precludes recovery [ftip-00BR]AGENTDRAFTED
The source records controls on both sides of the proposed implication. Its ScaledGD-inspired control is equivariant but equalizes the spectral schedule and does not recover the planted low-rank target at the declared budget. A long-anneal sign update is non-equivariant but eventually reaches a low-recovery-error regime.
The controls are reported in Remark 4.7 and Appendix D.10 of The loss does not see the basis, but Adam does[singh2026lossbasis]. The source reports no tuned reproducibility baseline for the ScaledGD control. The diagram is not a convergence theorem.
Optimizer geometry in training interventions [ftip-00BS]AGENTDRAFTED
Optimizer geometry in training interventions [ftip-00BS]AGENTDRAFTED
Equivalent parameterizations need not follow equivalent training trajectories. Their evolution also depends on the update geometry; the scalar loss and represented starting object do not always suffice.
Definition. Objective-equivalent parameterizations [ftip-00BT]AGENTDRAFTED
Definition. Objective-equivalent parameterizations [ftip-00BT]AGENTDRAFTED
Two factor pairs \((U,V)\) and \((\widetilde U,\widetilde V)\) are objective-equivalent for \(L=f\circ W\) when
\[ W(U,V)=W(\widetilde U,\widetilde V). \]They then have the same scalar loss for every objective depending only on that represented matrix. Orthogonal gauge-related pairs are objective-equivalent by Lemma [ftip-00AY]; objective equivalence need not imply membership in the same orthogonal orbit.
Definition. Parameterization-stable training intervention [ftip-00BU]AGENTDRAFTED
Definition. Parameterization-stable training intervention [ftip-00BU]AGENTDRAFTED
Fix a factorized objective, an update algorithm, hyperparameter schedule, randomness coupling, stopping rule, and initial optimizer state. The resulting training intervention is parameterization-stable on an orthogonal orbit when every two gauge-related initial states have identical represented trajectories:
\[ \widetilde U_t\widetilde V_t^{\mathsf T}=U_tV_t^{\mathsf T} \qquad \hbox {at every compared step }t. \]This is a local stability property of a fully declared intervention. It does not say that arbitrary objective-equivalent pairs outside the orbit must agree.
Proposition. Gauge equivariance gives parameterization stability [ftip-00BV]AGENTDRAFTED
Proposition. Gauge equivariance gives parameterization stability [ftip-00BV]AGENTDRAFTED
Every gauge-equivariant optimizer is parameterization-stable on each orthogonal orbit, provided the remaining protocol coordinates are coupled as in Definition [ftip-00BU].
Proof.
Proof.
Definition [ftip-00B3] gives \((\widetilde U_t,\widetilde V_t)=(U_tQ,V_tQ)\). Hence
\[ \widetilde U_t\widetilde V_t^{\mathsf T} =U_tQQ^{\mathsf T}V_t^{\mathsf T}=U_tV_t^{\mathsf T}. \]This is a sufficient condition on a declared orbit, not a claim that equivariance is necessary for every possible equality of represented trajectories.
Proposition. A first-step defect falsifies a loss-only protocol specification [ftip-00BW]AGENTDRAFTED
Proposition. A first-step defect falsifies a loss-only protocol specification [ftip-00BW]AGENTDRAFTED
Suppose two orthogonally gauge-related initializations have equal represented object and scalar objective, but a declared update produces different represented objects after one step. Then the training intervention is not determined by the represented initialization and scalar objective alone.
Proof.
Proof.
If those two objects determined the intervention, equal inputs would give the same represented next state. The witnessed inequality contradicts that factorization.
Proposition Proposition [ftip-00BE] and Example [ftip-00BF] instantiate its premise for one factored quadratic and zero-state Adam. It proves underspecification, not a capability difference.
Example. The orthogonal gauge of an attention head [ftip-00BX]AGENTDRAFTED
Example. The orthogonal gauge of an attention head [ftip-00BX]AGENTDRAFTED
For the row-vector attention weights of Definition [ftip-000P], let \(W^Q,W^K\in \mathbb R^{d\times d_h}\) and \(Q_h=XW^Q\), \(K_h=XW^K\). Attention logits depend on these weights through
\[ Q_hK_h^{\mathsf T}=XW^Q(W^K)^{\mathsf T}X^{\mathsf T}. \]For \(A\in \mathrm O(d_h)\), the right action \((W^Q,W^K)\mapsto (W^QA,W^KA)\) preserves the middle product.
Section 6 of The loss does not see the basis, but Adam does[singh2026lossbasis] uses column-vector weights and the invariant \(W_Q^{\mathsf T}W_K\). Transposition gives the row-vector invariant \(W^Q(W^K)^{\mathsf T}\), with the action on the right as displayed.
Remark. What the attention-twin experiment observes [ftip-00BY]AGENTDRAFTED
Remark. What the attention-twin experiment observes [ftip-00BY]AGENTDRAFTED
Section 6 and Table 3 of The loss does not see the basis, but Adam does[singh2026lossbasis] compare two function-equivalent initializations of a two-layer, four-head transformer on modular addition. The reported relative logit distance after one Adam step is \(3.6\times 10^{-3}\), versus \(2.9\times 10^{-7}\) for a same-basis noise twin; the final per-head invariant distance is reported as 56 percent.
The exact first-step defect has an algebraic explanation, but later drift, scale robustness, and downstream behavior are empirical. The tested small transformers, precision, optimizer allocation, seeds, and task do not establish a frontier-wide law.
Example. One loss quotient and two optimizer trajectories [ftip-00BZ]AGENTDRAFTED
Example. One loss quotient and two optimizer trajectories [ftip-00BZ]AGENTDRAFTED
A loss-only description collapses a gauge orbit to one represented starting point. A basis-sensitive optimizer can split that quotient back into different represented trajectories.
The right-hand split is possible only because the centre box omits the factor basis and optimizer geometry. An FTIP admissible protocol in Definition [ftip-005J] must retain those intervention coordinates when they affect the executable result.
Remark. Product symmetry and the scope of optimizer conclusions [ftip-00C0]AGENTDRAFTED
Remark. Product symmetry and the scope of optimizer conclusions [ftip-00C0]AGENTDRAFTED
The relevant optimizer results appear in version 1 of [⧉], submitted 5 August 2026: Sections 3--4 and 6, Appendices B.1--B.6 and B.9, with limitations in Section 11.
The full product symmetry acts on the factors by
\[ (U,V)\longmapsto (UA,VA^{-\mathsf T}). \]It does not use \((UA,VA)\). For row-vector attention weights, the corresponding action uses right multiplication, as in Example [ftip-00BX].
The general rectangular preconditioner representation need not have the square-case uniqueness. A probability-one full-rank claim additionally needs a law for the gradient; a generic full-rank observation does not specify one.
The coordinatewise theorem is a zero-state, memoryless obstruction. The clock theorem is continuous-time and excludes scalar-Adam's momentum. Experimental optimizer and attention results remain observations reported by the source. Equivariance is not identified with low-rank recovery.
Remark. Continuous-flow conclusions and discrete optimization [ftip-00C1]AGENTDRAFTED
Remark. Continuous-flow conclusions and discrete optimization [ftip-00C1]AGENTDRAFTED
The factored-model results prove that update geometry can be a genuine intervention coordinate even when objective and represented initialization are fixed. They do not prove transformer or RLVR convergence, practical optimizer superiority, a scaling law, or any change in reliable capability. Different represented trajectories are not by themselves an acquisition witness of Definition [ftip-005X].
The memoryless theorem does not describe Adam's full state, and the continuous-flow result does not supply discrete rates or finite-step bounds. The source also notes that fixed-rank LoRA changes the learned-rank mechanism; no LoRA transfer is made here.
A dynamic-compute comparison also depends on active research state, persistent harness state, retained history, evaluation configuration, and descendant and retry costs. One realized chain and an archive-best envelope are different outcomes, even at the same declared budget.
Definition. optimizer update support and effective rank [ftip-00OX]AGENTDRAFTED
Definition. optimizer update support and effective rank [ftip-00OX]AGENTDRAFTED
The source question is whether reinforcement-learning updates need the momentum and per-parameter adaptive rates supplied by AdamW. Mukherjee et al. compare SGD, SGD with momentum, RMSProp, and AdamW in GRPO and PPO settings across mathematical, coding, and adaptive-verifiable environments ([mukherjee2026adam, Sections 4-6 and conclusion]). In the reported runs, SGD matches or often exceeds AdamW, while its updates are substantially sparser and lower-rank; the source reports fewer than \(0.02\) percent changed parameters in representative cases and a 15.7 GB peak-memory reduction for Qwen3-1.7B. These are observations about the stated models, data, precision, threshold, seeds, and budgets.
The relevant FTIP intervention is therefore a tuple, not an optimizer name: model and checkpoint, RL algorithm, prompt and environment laws, optimizer and hyperparameters, numerical precision, update-support rule, effective-rank rule, training and evaluation budgets, and the held-out capability interface. A reported reward or pass rate does not identify the update geometry that produced it.
Let \(\theta _0\) and \(\theta _1\) be the parameters before and after a declared finite intervention, with \(n\) trainable scalar parameters. For threshold \(\varepsilon >0\), define \[ S_{\varepsilon }(\theta _0,\theta _1)= \frac {1}{n}\#\{i:|\theta _{1,i}-\theta _{0,i}|>\varepsilon \}, \]and, for every two-dimensional weight update \(\Delta W\), let \(\operatorname {rank}_{.99}(\Delta W)\) be the least number of singular values whose squared sum reaches 99 percent of the total squared singular-value sum. A study must report the threshold, precision, tensor selection, and aggregation rule alongside these numbers. The source uses bf16 and a \(10^{-5}\) threshold for its sparsity calculation; that convention is a source field, not a universal definition.
A matched Phase B comparison holds model family, checkpoint, training data and order, token and environment steps, rollout limits, precision, gradient accumulation, seeds, evaluation prompts, and stopping rule fixed while changing SGD or AdamW. Learning-rate and optimizer tuning must use the same predeclared trial count, search ranges, selection data, and tuning seeds, with tuning tokens, steps, wall-clock, and energy charged to both arms. The protocol also declares an optimizer-state memory cap (or explicitly reports no cap) and records persistent-state bytes, peak memory, wall-clock and energy, update support, effective rank, verifier/evaluator cost, and a prespecified held-out transfer task. Capability change and support change are reported as separate outcomes; a lower-rank update is not itself an acquisition witness.
The source does not establish general SGD superiority, a universal low-rank plasticity law, or transfer to long-horizon agents. Deep Delta's learned read/compare/write mechanism changes a different coordinate and remains in the later recurrence/rewrite batch.
Conceptual discovery across model generations [ftip-00MH]AGENTDRAFTED
Conceptual discovery across model generations [ftip-00MH]AGENTDRAFTED
The preceding chapters specify the model and learning mechanisms, retained agent state, evaluation and costs, with architecture-dependent refinements when needed. This chapter combines them in a question about capability growth across successive learned artifacts.
A mathematical breakthrough may require a new representation, a useful invariant, or a connection to another domain. The question is whether a specified model lineage can discover and acquire that structure within its resources, including by improving its own search and training procedures. An external contribution might make the same capability affordable.
This is a proposed separation between complete processes. A plateau in one training recipe does not establish it. Nor does the size of unexplored mathematics imply that current architectures can only recombine a fixed stock of ideas. Useful structure may be generated implicitly by updates, through analogy, or by programs constructed during the campaign.
The acquisition question in Definition [ftip-0007] therefore extends across successive learned artifacts. The finite discovery estimates of § [ftip-0076] apply only when their probability premises cover that evolving process. The finite controller certificate in § [ftip-00M8] illustrates an upper-bound method for a fully specified action class.
Readers entering through mathematical research should use the same sequence as the broader chapter: establish the lineage and acquisition criterion, inspect the contributor and conjecture context, then read the research profile, semantic records and assays. That route keeps the capabilities of finding, transferring, recombining and constructing ideas distinct from the historical question of whether an idea is genuinely new.
The complete lineage and its resources [ftip-00MI]AGENTDRAFTED
The complete lineage and its resources [ftip-00MI]AGENTDRAFTED
The comparison starts from disclosed artifacts and executable operations. A lineage includes the models it trains, the controllers it writes, and the evidence it retains. Its limits cannot be inferred from the support of one initial decoder while allowing the rest of the system to change.
Definition. A resource-bounded model lineage [ftip-00MJ]AGENTDRAFTED
Definition. A resource-bounded model lineage [ftip-00MJ]AGENTDRAFTED
Fix a specification
\[ \Xi =(I_0,\mathcal C_0,\Gamma ,\mathcal E_0,V, \mathcal D,\mathcal F,\mathbf B,\mathbf b_{\mathrm {eval}}). \]Here \(I_0\) contains the initial models, corpora, libraries, prompts, optimizers, evaluators, software and cached results. The nonempty class \(\mathcal C_0\) specifies controller programs and constants available from \(I_0\); it does not grant an arbitrary program chosen after a discovery. An initial generator of additional controllers is allowed, with its generation and selection work charged as explained in Convention [ftip-00N6]. The semantics \(\Gamma \) specifies executable operations and costs; \(\mathcal E_0\) specifies baseline observations and tool-response laws. The checker \(V\), task law and reveal schedule \(\mathcal D\), allowed final artifacts \(\mathcal F\), campaign cap \(\mathbf B\) and deployment cap \(\mathbf b_{\mathrm {eval}}\) are fixed before evaluation. Include the no-update procedure as a baseline.
A campaign is a causal execution starting from this endowment. Its state contains available checkpoints, contexts, generated code, retained traces, libraries, optimizer state and resource usage. A controller may use only its charged accessible state: discarded history must be reconstructed at cost. Environment state may remain hidden. All random seeds follow their declared laws; a fortunate completed trajectory is not an available program.
Whenever admitted by \(\Gamma \), operations include model inference, proof and program search, tool calls, parallel workers, memory management, candidate comparison, reward and credit assignment, synthetic tasks, parameter training, architecture changes, and controller replacement. Generated controllers execute under the same semantics and caps. Selection, evaluation and the controller's own computation are charged. These operations may recur in any order; learning need not first produce a complete successful trace or an explicitly verbalized idea.
The lineage is closed relative to \((I_0,\mathcal E_0)\) when its only campaign inputs are scheduled tasks, its randomness and admitted environment responses. This allows computation to reveal useful structure. A simulator using independent randomness is different from a tool observing new hidden world state; the latter access belongs in \(\mathcal E_0\).
Controller selection is independent of unrevealed instance seeds, conditional on declared public family information. This alone does not exclude family-wide answer tables: all such constants and preprocessing belong in \(I_0\). An asymptotic claim specifies uniform generation across instance sizes or explicitly accounts for nonuniform advice and preparation.
Definition. Hard resource accounting across generations [ftip-00MK]AGENTDRAFTED
Definition. Hard resource accounting across generations [ftip-00MK]AGENTDRAFTED
For a realized campaign \(\zeta \), let \(\mathbf R(\zeta )\) record inference work, training work, tool and checker work, total accelerator time, peak live memory and storage, peak allocated hardware, wall time and money under the declared operational model. Admission requires
\[\mathbf R(\zeta )\preceq \mathbf B\quad \text {almost surely}.\]Stop before an unaffordable operation; a missing result scores zero. Charge every failed path, discarded trace, evaluator call, consultation, checkpoint comparison and update. Bound the number of transitions by charged elementary work or an explicit finite horizon: infinitely many free operations are not admitted.
For additive work coordinates, a portfolio costs shared development plus the sum of task-specific work. Shared training is charged once even when it benefits many tasks. Peak resources and elapsed time come from the actual joint schedule, including communication and sequential dependencies. Parallel work is summed across workers. An expected-cost bound does not replace this hard cap.
A scalar budget \(B\) is used only after choosing one resource or a declared conversion with the remaining constraints fixed. Human time, accelerator work and elapsed time have no implicit exchange rate. Model pretraining and contributor expertise may be disclosed sunk endowments in a marginal comparison. A lifetime-cost claim must also account for producing both; unknown historical costs remain unknown.
Discovery and acquired capability [ftip-00ML]AGENTDRAFTED
Discovery and acquired capability [ftip-00ML]AGENTDRAFTED
A contribution can help solve a current problem without becoming a reusable ability. Discovery and acquisition are therefore separate outcomes, both evaluated against a fixed mathematical truth contract.
Definition. Signed discovery and fresh-task acquisition [ftip-00MM]AGENTDRAFTED
Definition. Signed discovery and fresh-task acquisition [ftip-00MM]AGENTDRAFTED
Fix the statement translation, allowed axioms, formal library and certificate checker \(V\). An answer is a sign \(\sigma \in \{+,-\}\) and a certificate \(p\). Put \(s_V(x,(\sigma ,p))=1\) when \(V\) accepts \(p\) as a proof of \(x\) for sign \(+\), or of \(\neg x\) for sign \(-\); otherwise put \(s_V=0\). The failure output \(\bot \) scores zero. A proof of excluded middle without either signed certificate does not solve the task. A task family may assume one signed certificate exists; independence from the allowed axioms is otherwise a separate source of failure.
For a current portfolio \(x_1,\ldots ,x_n\) with fixed nonnegative weights \(w_i\) summing to one, a campaign \(P\) has discovery score
\[Q_{\mathrm {disc}}(P)=\mathbb E\sum _{i=1}^n w_i s_V(x_i,P_i).\]For one fixed conjecture use a singleton portfolio; its truth need not be randomized. The expectation includes the declared task and execution randomness, with no assumption of independent attempts.
After development, freeze an artifact \(A\in \mathcal F\cup \{\bot \}\) before revealing fresh problems \(x'_1,\ldots ,x'_m\), where \(m\geq 1\). Their identities and solutions are unavailable during development; they are conditionally independent of development draws given the declared task-family variable. With a fixed deployment procedure \(\mathrm {Deploy}\), define
\[ Q_{\mathrm {acq}}(P)=\mathbb E\frac 1m\sum _{j=1}^m s_V(x'_j,\mathrm {Deploy}(A,x'_j;\mathbf b_{\mathrm {eval}})). \]Remove contributor access and feedback into training or checkpoint selection. Any permitted adaptation within one test problem is charged and discarded before the next. Evaluation work counts in the campaign; the per-problem cap is common to both arms. Deployment of \(\bot \) fails.
For model acquisition, \(\mathcal F\) contains learned parameters or adapters with a common fixed harness. For system acquisition it may instead include a bounded acquired library or controller. State which is measured. The pair \((Q_{\mathrm {disc}},Q_{\mathrm {acq}})\) does not allow success on one coordinate to conceal failure on the other. Imported mathematical results and new proof notation require sound translation under \(V\), including the cost of expanding and checking certificates.
Affordable complementary contributions [ftip-00MT]AGENTDRAFTED
Affordable complementary contributions [ftip-00MT]AGENTDRAFTED
The recipient is the learning system that receives and processes a contribution. Its interaction protocol specifies the permitted tools, retained state and update procedures. The contributor is the source of that contribution.
A contributor can make a representation, analogy, criticism, discriminating question or research direction affordably available to a recipient. The relevant properties are the interaction it can produce and what the recipient can make of it. Architecture, culture, expertise and developmental history can explain these properties without becoming mandatory coordinates of the abstract definition.
The convex-hull grades and contribution evidence note supplies a separate evidence convention for transfer, remixing and constructive invention.
Availability, structural quality and realized benefit require different arguments. A familiar connection can be novel to a learner's affordable repertoire, while a surprising sentence may be useless. The existence of infinitely many possible patterns supplies neither a probability of useful help nor an unaided computational lower bound.
Convention. Convex-hull grades and contribution evidence [ftip-00OS]AGENTDRAFTED
Convention. Convex-hull grades and contribution evidence [ftip-00OS]AGENTDRAFTED
Fix a recipient's declared initial endowment, a contribution transcript, a research task and an independent evidence standard. A hull grade classifies the strongest contribution claim supported by that transcript. It is a profile of the contribution's conceptual role, not a scalar ranking of the contributor or a replacement for correctness, importance, difficulty, attribution or cost.
Trajectory-level evidence for a claimed change of local idea basin follows the idea-basin and research-trajectory convention. The basin descriptor and horizon qualify the evidence without changing the hull grades below.
- Inherited framework (0.5). The transcript uses a method or framework already admitted as part of the recipient's endowment. A contribution can still be useful through explanation, execution or verification, but it adds no supported hull level.
- Rediscovery (1). The recipient reconstructs a known method or result without receiving its completed construction through the permitted channel. The reconstruction must satisfy the frozen correctness contract.
- Essential connection (2). The recipient recognizes and applies a relevant concept from another source, domain or representation. This is associative application, and it is the basic form of conceptual transfer. The evidence must identify the source structure, the transfer map, and a target result that depends on the connection.
- New architecture (3). The transcript supplies a composition or organization of resources whose interface changes the method's operation. The claim requires an essential dependency on that organization, together with fresh-task evidence and a charged construction record.
- Beyond. The transcript supports a new conceptual resource: a precisely diagnosed obstruction, a portable reformulation, a positive construction that fills the hole, consequences outside the original target, and independent evidence that the resource was not supplied in the starting endowment. This is the evidence standard for imaginative construction, not a synonym for surprising wording or a high benchmark score.
The same transcript can receive two novelty labels. Agent-relative novelty asks whether the resource was absent from the recipient's affordable initial repertoire. Historical novelty asks whether the resource was new relative to the declared mathematical or scientific background. Agent-relative novelty can be substantial while historical novelty is zero; a historical claim cannot be inferred from a learner's surprise. Report both labels and do not use either as a proxy for truth.
A grade is assigned only after checking the relevant evidence. Retrieval, transfer, remixing, construction, consequence and acquisition are separate observations in the research-capability profile. A transcript may show a successful transfer and fail the construction standard, or show a new construction whose proof is still unresolved. The final grade records the highest supported level and the unresolved lower-level failures.
This convention refines the convex-hull contribution proposal. It keeps the hull as an evidence-bearing classification while making the transfer and construction steps explicit. It does not assert that any current model or harness reaches a particular level.
Definition. A causal contribution process [ftip-00MU]AGENTDRAFTED
Definition. A causal contribution process [ftip-00MU]AGENTDRAFTED
Fix the recipient specification, task family, reveal schedule, interaction permissions and resource accounting. Abstract a contributor \(v\) by a causal interaction law, written as budget-indexed kernels
\[K_v^b(\mathrm dh\mid H).\]Here \(H\) is the history available to the contributor, \(b\) is its remaining contribution budget, and \(h\) includes the next message or failure/stop output with its joint resource record. The kernels arise from one consistent causal process under stopping: different budgets cannot be assigned unrelated ideal answers. No access to unrevealed test instances or their answers is permitted.
Two internal realizations are equivalent for this abstraction when they induce the same joint laws of transcripts, costs and stopping for every admitted recipient protocol and budget. Mathematically equivalent message contents need not be equivalent interactions: the recipient may find one encoding much easier to interpret or verify. A useful contribution may develop through several exchanges. Producing, interpreting, rejecting, correcting and learning from suggestions all consume resources.
Conditional theorems may assume properties of this interface without simulating a brain or reconstructing a civilization. An unconditional existence result additionally requires a realizable member of the assumed class, for example an executable source with disclosed initial state and costs. A controlled human protocol instead supplies empirical estimates. An arbitrary answer kernel or assumed success probability proves neither.
The target statements, truth contract, checker and reveal schedule stay fixed. Contributors may have different broad backgrounds or search biases; these endowment differences are disclosed. Relevant prior results must be justified under the target checker. A hidden target parameter or precomputed answer table is a different mechanism from conceptual insight. Equalizing all background material is an optional stronger comparison. Giving the recipient textual access to the relevant material can test whether acquiring and using the connection remains costly. Historical preparation follows the symmetric accounting convention in Definition [ftip-00MK].
Definition. Structural quality and good contributor classes [ftip-00MV]AGENTDRAFTED
Definition. Structural quality and good contributor classes [ftip-00MV]AGENTDRAFTED
Fix a development law and recipient interaction protocol \(\Pi \) before final evaluation. For development input \(D\) and resulting contribution transcript \(H_v\), choose an independently specified structural predicate \(S(D,H_v)\). Define
\[q_v=\Pr _{\Pi ,v}\bigl (S(D,H_v)\bigr ).\]A possible property is a sound reduction to a declared tractable class with bounded translation and certificate-expansion costs. A reusable invariant with a proved consequence or a curriculum satisfying a separate learning condition are other possibilities. A fallible analogy may require charged recipient completion before the property holds. The predicate is not simply that the final score improved; soundness, scope and checking costs require their own arguments. Quality is relative to this task, protocol and budget, not a universal ranking of minds.
For \(0<q_0\leq 1\), the restricted class
\[\mathcal G(q_0)=\{v\in \mathfrak V:q_v\geq q_0\}\]is legitimate. An existence theorem about a member of this class need not help every contributor outside it. Nonemptiness remains a separate obligation; choosing sources on final test outcomes does not establish pre-evaluation availability. Recruitment and screening costs are necessary when claiming an affordable procedure to find a good contributor, but mere existence does not require a population recruitment theorem.
To discuss a median, additionally declare a population law \(\mu \) on admissible contributors with measurable quality \(v\mapsto q_v\). Let \(q_{50}\) satisfy \(\mu (q_v\leq q_{50})\geq \frac 12\) and \(\mu (q_v\geq q_{50})\geq \frac 12\). Then define
\[\mathcal G_\mu (q_0)=\{v:q_v\geq \max (q_0,q_{50})\}.\]If \(q_0\leq q_{50}\), this class has at least half the population mass. If \(q_0>q_{50}\), even nonemptiness needs evidence. The median can be zero, so belonging to the upper half alone does not guarantee useful assistance. There is no default uniform law over all possible contributors, and an unattained quality supremum need not have a best contributor.
Proposition. From structural quality to acquired capability [ftip-00MW]AGENTDRAFTED
Proposition. From structural quality to acquired capability [ftip-00MW]AGENTDRAFTED
Fix one contributor and one recipient protocol with almost-sure total resource caps, including failed consultations. Let \(Z\in [0,1]\) be the realized fresh-task score of its frozen artifact with contributor access removed. Suppose, for the same joint process and remaining resources,
\[\Pr (S)\geq q_0>0,\qquad \mathbb E[Z\mid S]\geq \beta \geq 0.\]Then \(Q_{\mathrm {acq}}=\mathbb E Z\geq q_0\beta \).
Proof.
Proof.
Nonnegativity and conditional expectation give
\[\mathbb E Z\geq \mathbb E[Z\mathbf 1_S] =\Pr (S)\mathbb E[Z\mid S]\geq q_0\beta .\]No independence assumption is used. A uniform recipient guarantee for qualified transcripts and compatible development histories can establish the transfer premise, including interpretation, verification and acquisition costs. A guarantee for a different, easier message distribution cannot.
Together with a universal closed bound \(Q_{\mathrm {acq}}(P)\leq \tau ^-\) and an admissible member of \(\mathcal G(q_0)\), the strict inequality \(q_0\beta \geq \tau ^+>\tau ^-\) yields the assisted crossing in Conjecture [ftip-00MN]. The substantive obligations are affordable source quality, recipient transfer and the bound over every admitted unaided alternative. The elementary expectation inequality alone establishes none of these.
Proposition. Simulation can erase an apparent contribution advantage [ftip-00MX]AGENTDRAFTED
Proposition. Simulation can erase an apparent contribution advantage [ftip-00MX]AGENTDRAFTED
Fix a scalar accounting model with the other constraints declared. Suppose an admitted assisted campaign \((R,v)\) at total budget \(B\) has an admitted closed simulator at budget \(g(B)\). Require that the simulator can reproduce the contributor's endowment, observations and causal interaction, together with the recipient's allowed final artifact and evaluation law. All simulation work and initialization count. Then, for \(j\in \{\mathrm {disc},\mathrm {acq}\}\),
\[\sup _{P\in \mathcal L(g(B))}Q_j(P)\geq Q_j(R,v).\]
Proof.
Proof.
Couple the initial states and each successive conditional interaction using the stipulated simulator. Induction gives the same joint law of observable transcripts, final artifact and evaluated outcomes. The closed simulator therefore has the same score, and its admission places that score below the displayed supremum.
If the simulation is uniform across instance sizes with \(g(B)\leq cB\) for a fixed constant \(c\), an actual assisted procedure reaching \(\tau \) at work \(U(n)\) implies \(B_{\mathrm {closed}}(n,\tau )\leq cU(n)\). This excludes a lower bound \(L(n)\) with \(U(n)/L(n)\to 0\). Unavailable background state, observations, hardware or large simulation overhead can invalidate the premise; different origin alone does not. The argument does not assume that a language model already has an affordable simulation of a human contributor.
Admission includes discovery of any required reconstruction program from the declared initial state. A simulator written with advance knowledge of the useful representation does not satisfy this premise merely because its later execution is cheap. If the program is generated during the campaign, its generation law, failed attempts and selection costs belong in the simulation. This conditional proposition supplies no lower bound on that discovery cost; Convention [ftip-00N6] distinguishes program existence from its availability to the lineage.
Example. A human–agent exchange about conceptual discovery [ftip-00MY]AGENTDRAFTED
Example. A human–agent exchange about conceptual discovery [ftip-00MY]AGENTDRAFTED
In this exchange, the human is the contributor and the agent is the recipient: the system receiving and processing the contribution. The agent's proposals arose within an already human-directed conversation; they were not outputs of a separate unaided experiment.
- The agent proposed a resource-bounded formulation and a finite missing-evidence construction. The human rejected missing facts as the intended mechanism and described conceptual leaps across model generations: new perspectives, paradigms and connections between domains. The agent revised the target to conceptual discovery and separated prohibitive finite work from permanent unreachability using the enumeration countercheck.
- The agent specified an executable source with bounded observations. The human challenged an oracle-like abstraction, pointed to diverse cultural backgrounds and developed representations, and asked for an abstract account of what the source contributes. The agent formulated the causal contribution interface, with background differences disclosed rather than a mandatory model of a brain or lifetime.
- The human emphasized that existence of good contributors need not imply usefulness of all contributors, and suggested an upper-median restriction. The agent separated independent structural quality, class nonemptiness and recipient transfer, while showing why a median requires a population and need not have positive quality.
- The human suggested studying recursive self-improvement papers for the gap between the problems they diagnose and the portions their methods repair. The agent examined contemporary work and checked a revised primary source that narrowed stronger self-imitation claims. The resulting thesis distinguishes affordable quality, recipient acquisition and a universal unaided bound, with proof, refutation and precise obstacles all possible.
In Definition [ftip-00MU], \(H\) corresponds to the exchange so far and \(h\) to the human's next criticism, analogy or research direction. The agent's retained conversation and revised artifacts form its evolving state; reasoning, literature search and checking are its processing actions. The human did not supply a completed theorem: the assistance changed the problem representation and choice of inquiry. The observed outcome was a revised conjecture, before any fixed-target acquisition experiment. No structural-quality probability, cost advantage, held-out acquisition score or universal unaided bound was measured, so it does not establish the separation conjecture.
Conjecture. The conceptual-discovery conjecture [ftip-00MN]AGENTDRAFTED
Conjecture. The conceptual-discovery conjecture [ftip-00MN]AGENTDRAFTED
Fix the lineage specification and a separately specified admissible class \(\mathfrak V\) of contributors as in Definition [ftip-00MU]. A contributor interacts causally from its disclosed background within charged resources, without hidden target answers or unrevealed test inputs. Background knowledge may differ between arms; target statements, axioms, checker and test law remain fixed. The conjectured mechanism is making conceptual structure affordable to discover, recognize or acquire under those endowments.
Let \(\mathcal L(B)\) contain every closed campaign admitted by Definition [ftip-00MJ] under the chosen scalar cap and other fixed constraints. Let \(\mathcal A_v(B)\) contain admitted contributor–recipient campaigns, including contribution production, failed help, communication, interpretation, validation, training and evaluation in the cap. For some specified research family and initial lineage, conjecture thresholds \(0\leq \tau ^-<\tau ^+\leq 1\) and a realistic cap \(B\) such that
\[ \begin {gathered} \forall P\in \mathcal L(B),\qquad Q_{\mathrm {acq}}(P)\leq \tau ^-,\\ \exists v\in \mathfrak V,\ \exists R\in \mathcal A_v(B),\qquad Q_{\mathrm {acq}}(R)\geq \tau ^+. \end {gathered} \]This is not asserted for every task, model or budget. It allows unaided improvements below the threshold. A discovery version uses \(Q_{\mathrm {disc}}\); a joint claim requires the same assisted campaign to cross both thresholds. An abstract contributor class requires a realizable member for an unconditional existence result.
For a difficulty-indexed family and fixed \(0<\tau \leq 1\), define the closed work threshold by
\[ B_{\mathrm {closed}}(n,\tau )= \inf \{B:\sup _{P\in \mathcal L_n(B)}Q_{\mathrm {acq}}(P)\geq \tau \}, \qquad \inf \varnothing =+\infty . \]Define \(B_{\mathrm {assisted}}\) with the supremum over admissible contributors and recipients. A stronger asymptotic conjecture asks for positive functions \(L,U\) satisfying
\[ B_{\mathrm {closed}}(n,\tau )\geq L(n),\qquad B_{\mathrm {assisted}}(n,\tau )\leq U(n),\qquad \frac {U(n)}{L(n)}\longrightarrow 0. \]An operational crossing additionally requires an actual assisted procedure achieving \(\tau \) at work at most \(U(n)\) and a realistic cap \(U(n)\leq B_{\mathrm {real}}(n)<L(n)\). Suprema and infima alone need not be attained. Both inequalities remain conjectural for the intended mechanism. The proof-directed formulation in § [ftip-00N5] asks how developmental experience could yield the assisted construction and the closed lower bound.
Discovery without advance knowledge of the useful pattern [ftip-00N5]AGENTDRAFTED
Discovery without advance knowledge of the useful pattern [ftip-00N5]AGENTDRAFTED
Knowing how to construct a representation after someone identifies it is different from finding it during research. The relevant cost includes reaching a useful idea, recognizing enough of its value to act on it, and acquiring a capability that survives fresh evaluation. Each step may occur implicitly through learning; an explicit name for the idea is unnecessary.
Convention. Which discovery procedures are initially available? [ftip-00N6]AGENTDRAFTED
Convention. Which discovery procedures are initially available? [ftip-00N6]AGENTDRAFTED
The initial controller class in Definition [ftip-00MJ] is part of the endowment. It is not enlarged after an assisted discovery by inserting a program tailored to that discovery. A concrete specification can supply a finite collection of initial controllers, or an executable procedure that generates further controllers. In the latter case, generation, execution, comparison and selection occur within the campaign and consume its budget. The generator's fixed code and constants are themselves initial resources.
For example, let a campaign generate a program \(A_Z\) using a random variable \(Z\), and let its later interaction depend on the observed results. Its score averages over that declared generation and subsequent execution. Showing that one realization \(A_z\) constructs a useful representation cheaply does not show that the campaign finds that realization cheaply. Replacing the campaign by this selected program changes the initial endowment unless a legal route to its availability has been supplied.
This distinction does not forbid an ingenious algorithm. A procedure already admitted from the public task-family description is a legitimate closed alternative even if nobody has tested it. A lower bound must cover it. Conversely, a proof quantifying over all programs with arbitrary family-specific constants grants more advice than a fixed model lineage possesses. Uniformity across input sizes does not alone remove that advice: a single finite program can already contain the decisive family-wide idea. The theorem must state which controller access it grants.
An existential mathematical upper bound may describe a particular admitted program without proving that a person will discover its proof. The operational claim that a fixed lineage can acquire that program is stronger. It requires an available initial program or a charged causal construction from its accessible state. Keeping these claims distinct prevents both free advance knowledge and the exclusion of legitimate internal discoveries.
Definition. Every equally useful acquired solution [ftip-00N7]AGENTDRAFTED
Definition. Every equally useful acquired solution [ftip-00N7]AGENTDRAFTED
Fix a difficulty \(n\) and task-family parameter, the truth contract, fresh evaluation law and deployment cap of Definition [ftip-00MM]. For an allowed frozen artifact \(f\), including the failure artifact \(\bot \), let \(q_n(f)\) be its expected fresh-task score under that evaluation. The expectation includes fresh tasks and deployment randomness; set \(q_n(\bot )=0\). Evaluation begins with exactly the retained state permitted by the specification. Define
\[\mathcal U_{n,\tau }=\{f\in \mathcal F_n\cup \{\bot \}:q_n(f)\geq \tau \}.\]If the comparison randomizes a shared family parameter, apply this definition conditionally on that parameter and then average the resulting scores. This class is defined for mathematical analysis; membership need not be decidable or cheaply recognizable during research. It includes any artifact with the required performance: explicit lemmas, learned libraries, new architectures, implicit weights, and methods that avoid the contributor's representation entirely, whenever those artifacts are allowed.
For a random final artifact \(F_P\), the acquisition score is \(Q_{\mathrm {acq}}(P)=\mathbb E[q_n(F_P)]\). The desired lower bound must control this expectation for every admitted closed campaign. It cannot merely show that one named representation is unlikely to appear. Nor is a bound on reaching \(\mathcal U_{n,\tau }\) automatically a bound below \(\tau \): many outcomes just below the threshold can still have high mean score. A proposed proof must connect its event or structural quantity to the complete score distribution, as the explicit hypotheses of Proposition [ftip-00MP] illustrate.
The contributor need not transmit an entire solution. A question, analogy or example may change which experiments the recipient attempts. The resulting interpretation, validation and learning remain charged. Acquisition is established only by the frozen recipient's performance on fresh instances; an insightful exchange by itself establishes neither that performance nor a lower bound on unaided discovery.
Remark. From absent experience to a discovery lower bound [ftip-00N8]AGENTDRAFTED
Remark. From absent experience to a discovery lower bound [ftip-00N8]AGENTDRAFTED
The proof direction is to begin with a concrete developmental asymmetry: some task-relevant experience available to a contributor is absent from the lineage's initial data and observed traces. From a specified family and computational model, derive that acquiring any equally useful capability exceeds the closed budget. The absence of that experience is a premise. The absence of every affordable substitute is the desired conclusion, and must not be included as another premise.
Three arguments are needed. A bounded developmental process must produce reusable structure with a stated probability before fresh target instances are revealed. A charged interaction and learning procedure must turn that structure into recipient capability. A lower-bound argument must cover all closed histories admitted by the initial endowment and execution semantics, including adaptive tools, simulations, generated programs, training, changed architectures and alternative representations. The first two arguments describe a constructive assisted procedure; the third establishes why the closed lineage cannot match it at the chosen resources.
A necessary-event estimate becomes useful only after the family and operations justify both its necessity and its probability bound. Assuming that every successful route requires a rare conceptual event simply moves the central difficulty into an assumption. Likewise, absence from a corpus does not imply computational inaccessibility: affordable experiments or derivations may supply a substitute. A proof must explain what the particular environment makes accessible and why the admitted closed operations cannot obtain an equally useful substitute within budget.
Both inequalities in Conjecture [ftip-00MN] remain open for the intended conceptual-discovery mechanism. The conditional transfer estimate in Proposition [ftip-00MW] and simulation proposition in Proposition [ftip-00MX] do not prove them. The research objective is a positive separation proof, beginning with a sufficiently concrete account of development, access and cost. Any restriction used to make the mathematics tractable must be visible in the claim; a result for a narrow action class does not establish a ceiling for all model lineages.
Developmental experience and affordable discovery [ftip-00N9]AGENTDRAFTED
Developmental experience and affordable discovery [ftip-00N9]AGENTDRAFTED
A contributor arrives with a history of learning. That history may have made a useful invariant, decomposition or research direction easy to recognize long before the present problem arose. The proposed mechanism is that development changes which conceptual structures become accessible at reasonable cost. Different experience alone does not prove this effect.
The first comparison can isolate environment while holding the learning architecture fixed. This is a mathematical control, not a claim that human brains and current models have identical capabilities. A useful result under that control would not require architectural superiority.
Definition. A contributor produced by bounded development [ftip-00NA]AGENTDRAFTED
Definition. A contributor produced by bounded development [ftip-00NA]AGENTDRAFTED
Specify a developmental process by an architecture, initial state, learning and action rules, an environment response law, and hard resource caps. The process generates an interaction history and a retained state \(Z\); from that state it induces a contributor \(v_Z\) of Definition [ftip-00MU]. States include learned parameters, habits, libraries and memories. Their existence must follow from the declared development, rather than from choosing an arbitrary helpful state after seeing the evaluation.
An initial library or teacher may already embody earlier learning. Treat that preparation as a disclosed inherited endowment, or include a bounded process producing it. The controlled comparison must not credit the current environment with structure already present before development begins.
Development may include other learners, teachers, language, tools and related tasks. Their response laws and relevant preparation are part of the specification. The source's developmental randomness, failed learning and failed contributions remain in the joint score distribution. An existence claim can supply one explicit developmental process with a proved quality guarantee. Selecting a lucky realized graduate is different: an affordable selection procedure must account for screening and failures, as in Definition [ftip-00MV].
A task-family parameter may be shared between development and fresh evaluation, allowing experience to be relevant. The development law and source-selection rule are fixed before final instance seeds are sampled. Conditional on the declared family parameter, those seeds are independent of development. The contributor receives neither the unrevealed instances nor their answers. Broadly useful structure acquired on earlier tasks is allowed; a secret determining the final answers is a different mechanism from the conceptual discovery sought here.
To isolate the environmental contribution, one controlled comparison starts copies with the same architecture, initial state, learning rules and development caps, then varies only their environmental access. This can establish an environmental effect for those processes. The lower-bound claim is stronger: it must still cover every closed campaign admitted by Definition [ftip-00MJ], rather than only the one control learner used in that comparison. Architecture, initial artifacts and permitted learning changes must remain explicit when moving from this control to a human–model study.
Remark. Experience coverage and computational accessibility [ftip-00NB]AGENTDRAFTED
Remark. Experience coverage and computational accessibility [ftip-00NB]AGENTDRAFTED
The starting asymmetry concerns available experience: the lineage's initial corpora, memories and recorded traces do not contain some relevant part of the contributor's development. Literal absence is only a weak condition. Another description, a simulation, a derivation or a different experience may make an equally useful capability affordable. The claim in Remark [ftip-00N8] is to derive a bound covering these substitutes.
Three kinds of access should be distinguished. A stored trace gives particular observations and actions. Interactive access lets a learner choose actions based on its current state and receive the corresponding responses. Access to an executable environment model permits simulations, subject to the cost and fidelity of that model. None is automatically identical to either other kind: a finite trace need not determine responses to untried actions, while an accurate model can sometimes replace direct experience. Declare what the baseline actually has.
If environmental responses reveal a hidden bit that fixes the target answer, an information bound may be possible, but it proves a different mechanism. For conceptual discovery, retain a common mathematical truth contract and ask how development reveals reusable ways to search, represent or reason. The baseline may already contain enough information to compute the answer in principle. The proposed gap concerns the resources required to find and acquire an effective method.
A compact description of the acquired structure need not imply a cheap route to it. Description length, execution cost after identification, and discovery cost are different quantities. Conversely, declaring the structure absent from all affordable computations would assume the desired conclusion. Its inaccessibility must follow from the concrete task family, the supplied endowment and the admitted operations. Tools and simulations are charged operations within that argument, not an additional process outside the comparison.
Remark. Human and model growth as interacting learning processes [ftip-00NC]AGENTDRAFTED
Remark. Human and model growth as interacting learning processes [ftip-00NC]AGENTDRAFTED
A realistic comparison needs more than the contrast between a person who grows and a model that reads text. Human experience is selective and changes with the learner's actions and abilities. Models also inherit large bodies of human-produced data and can learn from video, interaction, feedback, generated tasks and earlier model generations. The relevant asymmetry is the particular developmental access and retained structure available in the specified comparison.
Smith and colleagues' 2018 review, The developing infant creates a curriculum for statistical learning, describes head-camera and eye-tracking evidence that infants' visual inputs change with posture, mobility and object manipulation. It proposes that these changing inputs can support a developmental curriculum. The authors leave the causal benefit of particular ordering and its relation to learning mechanisms as research questions. This motivates modelling learner-dependent experience; it does not establish an adult mathematical advantage or a lower bound for artificial learners.
Artificial learning already combines different forms of experience. In V-JEPA 2, Assran and colleagues pretrain visual representations on large-scale video, then train an action-conditioned predictor with robot interaction trajectories. The result supports planning for evaluated manipulation tasks. The relevant lesson is that recorded observations, action information and learned simulation can play different roles within one model's development. These results do not by themselves concern mathematical concept discovery.
The SIMA 2 report of November 2025 describes learning in new game environments using self-generated experience, with Gemini supplying tasks and estimated rewards, after initial learning from demonstrations. This is an example of a model lineage gaining skills through further interaction. Its teacher, environment access and retained experience belong in the baseline when available. The reported remaining difficulties with long tasks and memory are properties of that system, not universal limits of model growth.
These observations suggest comparing concrete interventions: preserve or shuffle a developmental sequence; provide selected traces or interactive access; add a bounded teacher; allow the lineage to design its own curriculum. Fix total resources and evaluate fresh-task acquisition after removing help. Such comparisons can identify which experience matters and guide a mathematical family. Even a large measured gap applies only to the tested procedures; proving the closed inequality still requires the broader argument in Remark [ftip-00N8].
Definition. Marginal assistance and the cost of development [ftip-00ND]AGENTDRAFTED
Definition. Marginal assistance and the cost of development [ftip-00ND]AGENTDRAFTED
A marginal comparison begins with a specified pretrained lineage and an already-developed contributor. It charges the closed campaign's new search and learning, and the assisted campaign's contribution production, failed help, communication, interpretation, checking and learning. Both face the same final evaluation and resource accounting. Their prior histories are disclosed endowments. A gap here means that assistance makes new acquisition affordable from those starting states; it does not mean that producing the contributor was cheaper than producing the model.
For an additive scalar work measure, let \(D_M\) be the model lineage's prior development, \(D_C\) the contributor's prior development not already included in \(D_M\), and \(W_0(m)\), \(W_1(m)\) the closed and assisted marginal work for a specified portfolio of \(m\) tasks. With any shared preparation charged once, the corresponding lifetime totals are
\[ \begin {aligned} T_0(m)&=D_M+W_0(m),\\ T_1(m)&=D_M+D_C+W_1(m). \end {aligned} \]Thus \(W_1(m)<W_0(m)\) need not imply \(T_1(m)<T_0(m)\). Shared expertise may be amortized across a declared portfolio; one cannot divide its cost by an arbitrary number of hypothetical future beneficiaries. Human-created training data, cultural resources, teachers and infrastructure follow the same inclusion convention on both sides. Unmeasured historical costs remain unmeasured.
The full resource comparison is a vector as in Definition [ftip-00MK]. Human time and accelerator work need an explicit conversion before a scalar inequality compares them. Wall time, peak hardware and memory follow the actual schedule, including causal dependencies. A model may copy states and run many experiments in parallel; an environment may impose an interaction rate. Whether simulation or accumulated experience can remove that delay is part of the setting, not an assumed advantage for either side.
A first proof target is marginal assistance, with bounded prior development specified separately. A lifetime comparison is a stronger additional question. Even with identical architectures, environmental access and prior duration can differ; equalizing architecture alone does not equalize all costs. State whether a claimed prohibitive expense is work, money, memory or elapsed time, and give the corresponding operational cap.
Remark. Settings for a developmental separation proof [ftip-00NE]AGENTDRAFTED
Remark. Settings for a developmental separation proof [ftip-00NE]AGENTDRAFTED
A promising mathematical setting couples related developmental tasks to a fresh target family through reusable structure. The contributor must acquire that structure by a bounded process. The recipient must then learn to use it under the common checker. The central choice is a family whose structure can both explain the developmental benefit and support a lower bound over the admitted closed alternatives. The following possibilities are research directions, not established separations.
One direction is a family of transformation puzzles with public local move rules. Development offers related tasks on which a learner can experiment, notice conserved quantities or discover a compositional decomposition. Fresh tasks ask for a checked move sequence or a certificate of impossibility. The acquired method must apply to new instances, and its certificates must fit the shared checker and deployment cap. This makes the intended assistance concrete without giving the contributor unrevealed answers. The missing argument is why the closed lineage cannot affordably discover any comparably useful invariant, decomposition or direct search method from the same public rules and its admitted tools.
A second direction studies the order and interaction of developmental experience. A learner's partial understanding can determine which question or intervention makes the next relation visible. Compare that process with the available passive traces and with any interactive or simulated substitutes admitted to the closed lineage. A proof must derive the cost of obtaining enough useful experience or processing the available data; simply withholding the interaction and declaring its outputs necessary would not explain conceptual discovery. Giving the lineage the same interaction channel is a stronger comparison when the intended mechanism is the cost of choosing how to use it.
A third direction studies a contributor drawing on cumulative cultural search. Several bounded learners develop, test and teach reusable concepts across earlier tasks. A current contributor's short suggestion may transmit structure produced by that longer process. This naturally motivates a marginal advantage and an amortization calculation. A lifetime advantage additionally requires accounting for that earlier population's work and for analogous shared data, teachers and parallel search available to model lineages. Culture must be generated by the declared process; a collection of perfect hints would assume its success.
For each direction, the proof needs a quantity that can be bounded through every admitted operation and connected to fresh-task performance. Information arguments apply when there is residual uncertainty; query arguments apply to explicitly limited response interfaces; computational arguments must address the available program class and its costs. If a separation is conditional on an independent computational hardness assumption, state that assumption and exhibit the reduction. Merely renaming the desired discovery difficulty as a hardness assumption adds no explanation. Restricted models can yield useful first results, provided their restrictions are not silently transferred to contemporary agents.
The most immediate constructive target is a development process that learns a reusable invariant on one task distribution and transfers it to fresh certified tasks. Alongside that construction, seek a family-specific lower bound covering every equally useful acquired method as in Definition [ftip-00N7]. Keep the model's own discovery, simulations and learning inside this argument. Neither the construction alone nor a failed search for substitutes proves the prohibitive closed cost.
§ [ftip-00NF] develops the first direction as a representation learner whose developmental experience also teaches it to construct a useful curriculum for another recipient. The concrete objects are the grounded representation, the learned teaching policy and their fresh-task effects.
Representation discovery through developmental curricula [ftip-00NF]AGENTDRAFTED
Representation discovery through developmental curricula [ftip-00NF]AGENTDRAFTED
A useful contribution can change how a learner represents a problem and how it learns to reason in that representation. The contributor may recognize a conserved quantity, a compositional structure or a distinction missing from the learner's present vocabulary. Its curriculum then makes that structure usable by another system. This combines two acquisition problems: discovering a grounded representation and discovering experiences that teach it.
The proposed construction uses related tasks with public transformation rules. A bounded developmental learner acquires representations and teaching procedures on earlier tasks; an initially separate recipient learns from its contribution and faces fresh certified tasks. The intended gain is less total acquisition work at a fixed success threshold. The construction below specifies the mechanisms to establish that gain. A successful learning process and a lower bound over every affordable closed alternative remain mathematical obligations, not consequences of specifying the setting.
A complementary acquisition problem is deciding which representations will matter before future demands are apparent. § [ftip-00NK] studies that prospective choice through a changing public task process.
Example. Public transformations and learned representations [ftip-00NG]AGENTDRAFTED
Example. Public transformations and learned representations [ftip-00NG]AGENTDRAFTED
Consider finite expressions built from a public grammar. A family parameter \(\theta \) specifies local rewrite rules and a distribution of problem sizes and compositions. The description of \(\theta \), the grammar and the rules are available to both campaigns. A target instance asks whether one expression can be transformed into another. An accepted answer contains either a legal rewrite sequence or a proof of impossibility in a fixed sound proof system. The generator produces instances with certificates of bounded size, retains those certificates for evaluation, and reveals only the instance to the learner. The checker, allowed proof rules and certificate-size cap are identical for assisted and closed campaigns.
Public rules make the intended difficulty computational. Earlier experience may teach consequences of the rules that are expensive to find from their description. It supplies no secret governing future answers. The family parameter, development law, evaluation distribution and resource caps are fixed before final seeds are sampled. Developmental and final seeds are independent conditional on \(\theta \). Intermediate learning tasks may be simpler than final tasks, but their relation to the final distribution must be specified by the generator rather than chosen after observing a favorable test result.
One possible learned representation consists of a map \(\phi \) from concrete expressions to abstract states, abstract operations, and procedures connecting abstract reasoning to checked concrete certificates. For example, a learner may discover that several rewrites preserve a quantity, or that large expressions decompose into components with a small interface. A soundness proof for the invariant or decomposition is part of the acquired method when it is used to certify an answer. Recognizing a pattern in a few examples is insufficient. Grounding here means computing the abstract description from the supplied expression and justifying the concrete consequences used by the solver.
The map may discard distinctions. If two expressions have the same abstract description but require different choices, a successful learner can refine the representation, retain a concrete side condition, or use another level of description. The cost of discovering the counterexample and implementing the revision counts. The task family should admit several sufficient methods: another invariant, a different decomposition, a compiled solver or direct search may succeed without reconstructing \(\phi \). Success is measured by checked answers, so equally useful implicit representations in model parameters also qualify.
This is a parameterized family design, not a claimed hard rewrite system. An explicit instance of the construction must give the grammar, rules, certified generator and learning procedures, then prove their performance. Families reducible to a cheap canonical form or direct search may demonstrate learning and transfer while offering no discovery-cost separation. That possibility is a substantive test of the proposed mechanism.
Definition. Learning to discover and teach a representation [ftip-00NH]AGENTDRAFTED
Definition. Learning to discover and teach a representation [ftip-00NH]AGENTDRAFTED
The contributor begins with the disclosed state and bounded development of Definition [ftip-00NA]. On related rewrite tasks it can propose predicates, execute public rules, test conjectures, build examples and revise its representation. Neither a completed invariant nor a successful curriculum is placed in its initial state unless that preparation is explicitly counted as an inherited endowment. A constructive success argument must describe how the development process produces useful structure with a stated probability, including failed attempts.
Teaching is a further learned action. Let \(Z_t\) be the contributor's retained state, \(h_t\) the observed interaction history and \(q_t\) an intermediate task or demonstration. A teaching policy chooses \(q_t\) from \(Z_t\) and \(h_t\); the recipient's response and checked learning progress supply feedback for later choices. The policy may first teach a distinction on small expressions, then ask for a general invariant, and finally require composition on larger expressions. These stages describe a possible mechanism. Their usefulness must be established for the specified learner, rather than assumed from the apparent pedagogical order.
During development, the contributor can practice with bounded copies of a declared recipient population. It learns which examples correct particular failures and when a new abstraction is worth introducing. The student updates used to evaluate a teaching proposal are real work: cloning, training, progress evaluation, rejected curricula and teacher updates all count. A progress set drawn from the development distribution can provide a verified reward. Final evaluation instances remain unavailable for curriculum selection. Any guarantee must connect development progress to fresh-task success, since a curriculum may overfit either the practiced recipient or its progress measure.
At assistance time, a fresh recipient starts from the declared model endowment. The contributor supplies an explanation, programs, examples or an adaptive sequence of tasks, within communication and interaction caps. The recipient must interpret the contribution, check the relevant claims and learn to use the representation. Evaluation occurs after the contributor is removed. A retained contributed program is allowed when it fits the common deployment interface and cap; merely consulting an uncharged external solver during evaluation is a different experiment.
Useful teaching need not require the teacher to solve the final tasks itself. Conversely, a source that can solve them may still fail to teach the recipient. Measuring the contributor's discovery, its teaching skill and the recipient's later capability separately makes these possibilities visible. A short explanation or a short successful curriculum measures transmission after discovery; its length does not establish that finding it was cheap or expensive.
Remark. Contemporary representation and curriculum learners [ftip-00NI]AGENTDRAFTED
Remark. Contemporary representation and curriculum learners [ftip-00NI]AGENTDRAFTED
Current agents already implement substantial parts of this construction. TheoryCoder-2 synthesizes PDDL abstractions alongside a learned Python dynamics model and hierarchical planning. Its discussion nevertheless identifies supplied object-oriented states and brittle predicate grounding as limitations. In its tested environments, an initial observation sufficed for adequate abstractions; learning to revise a representation through unfamiliar interventions remains a further problem. This motivates learning the concrete-to-abstract map, without implying that generated predicates are beyond model capabilities.
ProPlay learns a procedural graph with transition reliability to guide later action. Its failure analysis shows why reusable structure alone is insufficient: a coarse procedure can lose necessary quantitative detail, and a generally reliable transition can be unhelpful for the present task. Its plan is produced once per episode. The representation learner above must therefore be compared with agents allowed to revise plans and abstraction levels, not just with the particular implementation evaluated in that paper.
SOAR, especially its method, ablations and limitations, provides an automated teaching mechanism: teacher tasks receive reward through a student's improvement on a separate hard training set, without the teacher seeing those hard questions. Its substantial bilevel training cost and dependence on a ground-truth progress signal belong in the comparison. Failure on an initial finite sample does not prove that direct discovery is impossible.
Vocabulary Dropout for Curriculum Diversity shows that modifying proposal generation can sustain curriculum diversity, while its asymmetric proposer/solver experiment and verification analysis show that diversity and stronger teachers need not yield better learning. ANCORA combines supervised initialization, proposer/solver training and a filtered curriculum graph for verifier-based learning. Its limitations include diversity collapse within valid outputs and longer-run plateaus. Its Proposition 4.1 assumes continued positive probability of admitting new specifications; that premise does not establish the cost of discovering useful new concepts.
These results motivate a combined comparison with representation synthesis, curriculum generation, active experiments, persistent memory, search and model updates. Their reported benchmarks do not instantiate the rewrite construction or establish its separation. A contributor defined only as a supplier of abstractions, diverse exercises or a curriculum graph would duplicate mechanisms already available to the closed campaign. The remaining question concerns how much work any adequate combination needs to acquire useful structure from the specified starting state.
Convention. Fresh transfer and the discovery-cost argument [ftip-00NJ]AGENTDRAFTED
Convention. Fresh transfer and the discovery-cost argument [ftip-00NJ]AGENTDRAFTED
Fix a final success threshold and a resource vector before comparing methods. The assisted upper-bound problem is constructive: specify bounded development, a prospective source-selection procedure, contribution production and recipient learning, and establish their joint probability of reaching the threshold. Charge failed development and teaching runs where selection uses them. The marginal comparison discloses earlier contributor development separately; a lifetime claim includes that work under Definition [ftip-00ND]. Communication length, token count, accelerator work and elapsed time are distinct quantities unless an explicit conversion relates them.
Several controlled comparisons can locate the benefit. Giving the recipient a completed grounded representation measures acquisition after discovery. Replaying a successful curriculum measures learning after its selection. Replacing adaptive teaching with fixed examples tests the value of recipient feedback; varying the final expression size and composition tests reuse. A closed campaign that builds its own curricula, revises representations and updates its models tests affordable reconstruction. The supplied-representation and replay experiments are positive controls, not estimates of unaided discovery cost.
The mechanism predicts that a useful developmental curriculum reduces recipient work on unseen compositions, and that failures caused by lost abstract distinctions decrease after grounded refinement. If gains vanish when the source is removed, depend on near-duplicate evaluation instances, or disappear under a cheap alternative solver, the proposed explanation must change. Measuring these outcomes can reject a candidate construction. An observed advantage over the implemented comparison agents still leaves the all-campaign claim open.
For that claim, start with an arbitrary successful closed campaign in Definition [ftip-00MJ]. Its code search, implicit representations, retrieval, synthetic tasks, self-play, active interventions, training updates, heterogeneous models and resource-allocation choices are all admissible when allowed by the declared endowment and caps. The lower-bound argument must connect its checked fresh-task success to work that every such route incurs. It cannot require the campaign to discover the contributor's particular invariant or follow its curriculum. Direct solving is an alternative to conceptual reconstruction.
A family-specific reduction could show that any successful closed campaign solves an independently hard computational problem, while the bounded developmental process and assistance yield an affordable upper bound under the disclosed prior endowments. A restricted representation language or response interface may admit a first, narrower theorem. Neither case permits assuming that every useful curriculum or representation is negligibly likely under arbitrary adaptive search: that would assume the desired discovery barrier. The absence of the contributor's experience in Remark [ftip-00N8] supplies the starting condition; the prohibitive cost of every equivalent capability is still to be derived.
Prospective abstraction in evolving task families [ftip-00NK]AGENTDRAFTED
Prospective abstraction in evolving task families [ftip-00NK]AGENTDRAFTED
Some concepts become valuable because they prepare a learner for tasks that have not yet arrived. A contributor may learn how research demands evolve and invest in structure whose utility is poorly reflected by compression of past solutions. The acquired capability is a way to forecast, choose and revise abstractions under limited resources.
This differs from constructing a teaching curriculum in § [ftip-00NF]. There the source chooses experiences that help a recipient learn useful structure. Here the source learns about the process producing future demands, and uses that understanding to decide which structure is worth acquiring. Teaching can transmit the resulting capability, but does not define its prospective value. Informative experiments, cumulative culture and research judgment can support either process.
Definition. A public process for changing task demands [ftip-00NL]AGENTDRAFTED
Definition. A public process for changing task demands [ftip-00NL]AGENTDRAFTED
Extend the public rewrite setting of Example [ftip-00NG] by a sequence of demand states \(X_t\), with a declared initial distribution. A fixed transition law \(K_\theta \) governs how the demand state changes. Conditional on \(X_t\), a fixed generator \(G_\theta \) samples a certified task. The parameter \(\theta \), both laws and the rewrite rules are available to both campaigns. A demand state may favor particular compositions, expression sizes or interfaces, so an abstraction useful in one period need not remain useful in the next. The future random seeds are unrevealed, and the laws are fixed independently of either learner's decisions. The laws are given as computable programs; their execution and any derived approximation are charged.
For example, demand may move between tasks dominated by local cancellation, tasks requiring repeated composition, and tasks coupling several components through a shared boundary. This describes possible structure in the generator, not established difficulty of those tasks. The change law could make a local regularity predictive of later coupling, so acquiring a compositional representation has value before that coupling becomes common. An actual construction must specify the expressions, rules and transition probabilities, and show that its proposed investment really reduces later work.
A state \(X_t\) can be observed directly or inferred from the common history of revealed tasks and responses. Fix which case applies. If the state is latent, both campaigns receive the same observations; the source has no private reading of the current state or future seed. In the computational version, their problem is to process the available history and public laws cheaply enough. Uncertainty remaining even for an unlimited observer is common to both. Giving only the contributor an informative sensor or an undisclosed generator defines a separate information-access comparison.
Development uses earlier independently seeded episodes from the declared process family. It may teach a learner to recognize which histories predict useful future structure, but cannot supply the final episode's hidden state. Selection of the source and its retained state precedes final seeds. During evaluation, tasks arrive in order; any feedback and adaptation available after an answer follow the same specified schedule on both sides. The final correctness predicate, proof rules and certificate cap stay fixed throughout the changing demand distribution.
Definition. Joint acquisition of a forecast and a library [ftip-00NM]AGENTDRAFTED
Definition. Joint acquisition of a forecast and a library [ftip-00NM]AGENTDRAFTED
A developmental learner retains a predictive state \(b_t\) and a library \(L_t\) of representations, subroutines or reusable reasoning procedures. From the observed history it updates its forecast of future tasks and decides whether to extend, refine or discard library elements. The forecast need not be an explicit Bayesian posterior, and the library may be encoded in parameters. The defining feature is that the learner uses anticipated downstream utility in deciding what to acquire.
The two learning problems interact. A new representation can make a previously obscure regularity in the task process easier to recognize; a revised forecast can change which representation is worth learning. Consequently, a predictor operating over a fixed, human-supplied list of perfect abstractions removes part of the proposed acquisition problem. A bounded construction should describe how candidate structure is generated, how its consequences are grounded, and how experience updates both prediction and selection. Initial program libraries, pretrained predictors and demonstration histories remain disclosed endowments.
One possible developmental procedure generates candidate decompositions from earlier solved tasks, predicts their usefulness over a finite future horizon, and spends a capped amount of work testing the most promising candidates on independently sampled continuations. Failed predictions supply feedback. This is an explicit algorithmic pattern, not a free forecast oracle: generating continuations, constructing a simulator, evaluating candidates and revising the predictor all cost work. With public computable laws, the closed campaign may implement this procedure too. The intended advantage must come from the cost of acquiring a sufficiently useful procedure from the specified endowments.
A developed contributor can teach the recipient its selection method, transmit a grounded library with its conditions of use, or help initialize a predictor. The recipient must acquire and apply the contribution within the assistance cap. Later library selection and task solving are performed without further uncharged source access. A one-time selection for a revealed history is a weaker form of help than learning a reusable prospective policy; transfer to fresh episodes distinguishes them. Neither form requires matching the source's internal concepts.
Remark. Prospective selection and contemporary agent alternatives [ftip-00NN]AGENTDRAFTED
Remark. Prospective selection and contemporary agent alternatives [ftip-00NN]AGENTDRAFTED
Prospective Compression in Human Abstraction Learning studies reusable-helper choices while a latent curriculum changes. Its two controlled Pattern Builder experiments involve 60 participants in total and six computational comparison models. The results support sensitivity to future reusable structure beyond the tested retrospective and LLM-based accounts. They motivate studying prospective acquisition rather than only compression of earlier solutions.
The paper's limitations are decisive for the comparison here. It does not implement a full learner that infers the latent task-generating process, and individual tasks can be solved without reproducing human helper choices. Its restricted helper-optimization hardness result does not bound arbitrary learning agents. The proposed construction therefore evaluates checked future performance and total work, rather than similarity to human-selected helpers, and admits agents that jointly learn a process model and a library.
Such agents may forecast by Bayesian inference, learned world models, sequence prediction or simulation; select structure by search, expected utility or learned value estimates; and retain experience in memory or model updates. ProPlay supplies one contemporary procedural-memory mechanism, while BREW constructs reusable recipes from trajectories and optimizes their correctness and retrieval usefulness. These particular systems do not establish prospective learning for the public rewrite process, but their mechanisms are available components of an alternative campaign.
Theoretical active-inference guarantees also require attention to what is already supplied. Curiosity is Knowledge proves results under stated identifiability and regularity conditions; its discussion identifies idealizations including a discrete hypothesis setting and exact mutual-information computation. Providing an adequate hypothesis class or an exact acquisition calculation can remove work that the developmental construction is meant to explain. Conversely, these restrictions do not establish that a more general agent cannot find an affordable approximation or a different sufficient method.
Remark. Experiments, cultural preparation and research judgment [ftip-00NO]AGENTDRAFTED
Remark. Experiments, cultural preparation and research judgment [ftip-00NO]AGENTDRAFTED
Informative experiments can improve either representation discovery or forecasts of future demand. A contributor may learn which intervention distinguishes plausible decompositions or exposes a misleading progress measure. In the public-rule setting, both campaigns can execute the same permitted experiments; the question is the cost of choosing and interpreting them. Criticality-guided learning learns to target failure-prone conditions from execution outcomes, showing why rarity under random sampling is too weak an argument. Its predefined state representations remain a relevant limitation of that implementation. A physical experiment with unequal access may support a different, explicitly informational or interaction-rate result.
Cultural preparation can supply earlier exploration, tested concepts and teaching practices. Model it as a bounded population that generates, selects and transmits methods, or disclose its products as inherited endowments. Failed discoveries, selection and transmission count; so do analogous shared data, model populations and libraries on the closed side. The study of AI-discovered strategies in human culture separates difficulty of discovery, ease of transmission and recognizable advantage. Its AI-to-human direction supports an origin-neutral contribution. Neither that experiment nor its population simulations establish a general discovery lower bound. Prior cultural work can explain a marginal benefit, while lifetime and amortized claims require the accounting in Definition [ftip-00ND].
Research judgment can help choose a fruitful subproblem, recognize when an abstraction loses an essential distinction, or improve an intermediate progress measure. Such choices affect how computation is spent; they do not change the final mathematical task or checker. The study of divergence and negation in scientific ideas reports differences between expert ratings and several automated evaluations, while also showing benefits from learning a reward model on human ratings. This motivates acquired judgment without treating it as a human monopoly. Expert ratings of ideas do not directly certify mathematical discovery. For this construction, any learned progress measure must justify its value through fresh checked outcomes, with its own training and validation charged.
These three contributions have distinct roles: experiments produce useful evidence, culture explains how prior useful structure was generated and transmitted, and judgment guides selection and evaluation. They can support both major constructions, but their benefits do not automatically add. A curriculum learned from cultural demonstrations and selected by an experimental progress measure may share preparation across all three. Ablations should vary one mechanism at a time, and total accounting should charge shared work once.
Definition. Future utility, investment cost and proof scope [ftip-00NP]AGENTDRAFTED
Definition. Future utility, investment cost and proof scope [ftip-00NP]AGENTDRAFTED
Fix a horizon \(H\), a success threshold and a common adaptation schedule. In an additive work measure, let \(A_t\) charge forecasting, experiments and library construction before task \(t\), and let \(S_t\) charge solving, checking and permitted learning from that task. Let \(I\) charge assistance production, communication and recipient acquisition. The assisted marginal work is
\[W_1=I+\sum _{t=1}^{H}(A_t+S_t).\]The closed total charges its corresponding acquisition and task work under the same convention. Forecasts may optimize expected future work, but a hard budget claim must also bound realized resource use and include runs that exhaust the cap in the success probability. Memory, peak hardware and elapsed time retain their separate operational constraints. Earlier development and any portfolio amortization follow Definition [ftip-00ND].
A useful prospective policy should reduce later acquisition and solving work enough to repay its earlier investment at the fixed success threshold. Compare it with retrospective compression, a learned generative-model policy, direct solving without a reusable library, and a campaign that constructs its own predictor and representations. Equalize current observations and disclose earlier preparation. An oracle given the future sequence can diagnose the maximum possible value of anticipation, but its performance does not establish that either real learner can obtain it.
The mechanism predicts a larger benefit when demand changes have learnable structure and the right abstractions require substantial advance investment. It predicts a smaller benefit when demand is uninformative, useful libraries are cheap to build on arrival, or direct solving already fits the cap. A predictor can be accurate yet unhelpful if its forecast does not change an affordable decision. Measure fresh-task success, realized work and the effect of forecast-guided investment together. These are testable predictions for the specified process, not reported experiments.
The constructive proof problem is to produce a bounded developmental learner and establish its later performance without hindsight selection or privileged final-episode information. The closed lower-bound problem must cover every equally useful selection or solving method in Definition [ftip-00N7], including implicit forecasts, alternate abstractions, heterogeneous learners and internally generated curricula. A lower bound only against retrospective compression would explain that restricted comparison, not the conjecture about contemporary closed campaigns.
For a computational separation with public laws, a reduction must connect fresh checked success to an independently hard inference or computation problem under the declared endowment and resource cap. It must also explain why direct solving and alternative investment policies cannot avoid that work. Withholding the future law from one side, choosing future tasks after seeing its library, or assuming every useful forecast is rare would establish a different claim or assume the desired conclusion. The prospective construction supplies a distinct acquisition problem; the all-campaign cost inequality remains open.
Mathematical research beyond initial ability [ftip-00NQ]AGENTDRAFTED
Mathematical research beyond initial ability [ftip-00NQ]AGENTDRAFTED
A mathematical agent can develop a method for a problem whose solution is already known to its evaluators. What matters for acquisition is the agent's starting ability, the research it performs, and the new problems it can solve afterward. Novel mathematics strengthens the discovery outcome, but withholding a known solution can make the development of a method observable under a precise standard of correctness.
This setting makes the developmental construction of § [ftip-00NF] concrete through mathematical research. A candidate concept is tested against objects and counterexamples, useful lemmas are retained, and a recipient acquires an artifact before fresh problems are revealed. The prospective question in § [ftip-00NK] concerns which such concepts are worth developing for future demands. Both questions admit successful autonomous discovery. The conceptual transfer and constructive invention profile separates diagnosis, transfer, remixing, construction, consequence, verification and acquisition so that a research trace can show which ability was exercised.
Definition. Conceptual transfer and constructive invention [ftip-00OR]AGENTDRAFTED
Definition. Conceptual transfer and constructive invention [ftip-00OR]AGENTDRAFTED
Fix a task family, an initial artifact, an admissible interaction protocol, and a charged resource cap. A research trace records how a system moves from a difficulty to a reusable capability. Its research-capability profile is a tuple of separately measured fields, not a scalar intelligence score:
\[ \mathcal I=(I_{\mathrm {diag}},I_{\mathrm {transfer}},I_{\mathrm {remix}}, I_{\mathrm {construct}},I_{\mathrm {consequence}},I_{\mathrm {verify}}, I_{\mathrm {acquire}}). \]The fields record, respectively, whether the system can diagnose a failed approach, move a useful concept across a stated boundary, combine several concepts, construct a resource that was not supplied, derive consequences, validate the result independently, and retain the capability after the research interaction ends. Each field is conditional on the task law, protocol, evidence standard and resource accounting; it may be unmeasured or inapplicable. The profile therefore complements the architecture-conditioned vector in Capability vector and conditional frontier without redefining its coordinates.
A conceptual transfer begins with a source concept and a target problem. It identifies the source's usable structure, gives a map or analogy that preserves the relevant relations, adapts the concept to the target representation, and supplies a checkable consequence. Merely mentioning a similar idea is retrieval; applying a relevant idea to a new problem is associative application. Transfer is established by the preserved structure and the target-side result, not by verbal resemblance.
A remix composes two or more source concepts whose joint use was not already supplied as a completed method. The trace must state the interface between the concepts, the new dependency or composition rule, and the result that depends essentially on that combination. A longer list of familiar steps is not a remix when no new relation is needed.
A constructive invention responds to a diagnosed obstruction. The system identifies a precise hole in the current representation or method, reformulates that hole as a portable difficulty, and constructs an object, representation, question or governing principle that fills it. A positive construction argument contains a checkable construction, an essential new resource, consequences beyond the original target, and an account of why the resource was not already present in the admitted starting material. This is the sense of imaginative construction used here; novelty is assessed relative to the declared endowment and also reported separately from historical novelty.
These operations have different failure boundaries. A system may diagnose an obstruction without transferring a concept, transfer a concept without remixing it, or construct a useful object without proving its consequences. Proof and independent verification remain separate fields. Acquisition adds a further condition: after the contributor, search aid or temporary context is removed, the frozen recipient must use the retained artifact on fresh tasks. A successful assisted answer alone does not establish retained capability.
The profile describes an ability under a specified setup. A tool, curriculum, contributor or persistent archive can facilitate an operation and can also become part of the retained artifact; the evidence must state which occurred. The profile is therefore compatible with model learning, external setup and successive model generations while keeping those causal routes distinct.
The profile develops the convex-hull discussion of contribution grades by making associative application, transfer, remixing and construction observable as different outcomes. The accompanying review of discovery mechanisms is an operational audit of these distinctions; it does not determine the capability definitions or establish a performance result.
Convention. Semantic records for conceptual discovery [ftip-00OT]AGENTDRAFTED
Convention. Semantic records for conceptual discovery [ftip-00OT]AGENTDRAFTED
A research trace is evidence-bearing when each important transition names its input, operation, output, cost and checking status. The following records are semantic slots; a human, model, tool or mixed process may fill them. They make the route from failure to reusable capability inspectable without treating a particular harness as the source of the ability.
- Obstruction. Record the attempted method, the instance or family on which it failed, the smallest verified reason for failure, and the evidence that the failure is relevant to the target rather than an implementation error.
- Difficulty problem. Reformulate the obstruction as a portable question. State what structure is missing, which boundary is held fixed, what would count as a solution, and which information is withheld from the research process. A vague request for a better idea is not a difficulty problem.
- Direction. Record a proposed route, its source domain or representation, its predicted obstruction or gain, its resource estimate, and the experiment or proof that could reject it. Diverse or opposite directions are useful only when their differences are explicit.
- Transfer map. Identify the source relations, the target objects, the map or analogy between them, the relations preserved, the adaptation needed, and the target-side certificate. This record separates conceptual transfer from a shared word or an untested analogy.
- Construction. State the new object, representation, question or principle; identify the hole it fills; list its essential dependencies; and record the construction, checking work and cost. If the construction uses a contributor, archive or temporary context, record that causal input separately.
- Consequence. State a result that follows from the construction and extends beyond the motivating instance. Include a fresh test, counterexample search or proof obligation that could invalidate the claimed consequence.
A complete trace may branch and may contain rejected records. Rejection is part of the evidence: the trace preserves the failed direction, the reason for rejection and the work charged to reach that decision. A successful transfer does not imply a successful construction, and a construction does not imply a proved consequence. Independent verification and frozen-recipient acquisition remain later records in the research-capability profile.
The record schema also separates ability from facilitation. The transcript names which information was available to the model, which operation was performed by an external setup, and which artifact remained after the setup was removed. Search, retrieval, communication, interpretation, checking and failed attempts are charged to the declared campaign. A record that omits these causal boundaries can document an assisted result but cannot identify a learned or retained capability.
These records support the hull-grade convention and the prospective controls in A prospective comparison of research campaigns. They are an evidence interface, not a benchmark score and not a claim that any current system fills every slot.
Definition. Idea basins and research trajectories [ftip-00OV]AGENTDRAFTED
Definition. Idea basins and research trajectories [ftip-00OV]AGENTDRAFTED
Fix a task family, an initial endowment, an interaction protocol, a resource cap and a state descriptor. Use the active research state as the base record; for this assay, a trajectory state records the current representation, proposed method, open obligations, retained artifacts and charged resource ledger. A research trajectory is a finite sequence of such states together with each operation, observation, failure or acceptance, provenance record and cost. Rejected directions remain in the trajectory because they show which work was attempted and why the method changed.
To make an idea basin testable, declare before the run a finite set of local operators, a canonicalization or equivalence test for states, a step horizon and a resource budget. The local state graph has an edge between canonical state classes when a declared operator changes one representative to another while passing the fixed protocol and checks. The basin of an initial state is the set of canonical state classes reachable by at most the declared number of local steps and within the declared budget. It is therefore relative to the chosen descriptor and local operators: a different neighborhood or horizon defines a different basin. Similar wording, more sampling or a longer trace does not by itself define a new basin.
A basin escape is a trajectory transition whose resulting state lies outside that declared reachable set and whose witness names the changed representation, decomposition, invariant, objective or search operator. The claim is supported only when the changed state passes an independent check and solves withheld or fresh tasks under the predeclared accounting. A local baseline with matched seeds and resources must be run in parallel, and failed escape attempts are retained as evidence. Escape is a claim relative to the declared neighborhood and horizon, not a proof of global mathematical novelty.
The [cai2026forkflush, Sections 3-4] study reports that independent runs on the same task can plateau in localized idea basins, and evaluates fork-and-flush interventions that preserve the workspace while starting a fresh chat context. The [zhang2026statelessagents, Section 2.2] study reports replayed histories, repeated work, premature stopping and continued token use without new experiments; its stateless, harness-reconstructed contexts and explicit assignments improve long-horizon progress in the tested software and systems tasks ([zhang2026statelessagents, Sections 3.1-3.2 and 4.2-4.3]). This supports the qualified inference that persistent conversational state can reinforce a decision or search basin, while harness-controlled reconstruction can expose alternative directions. Most configurations in that paper use one run ([zhang2026statelessagents, Section 4.1]), and it does not directly measure FTIP idea-basin membership.
The trajectory record separates discovery from evaluation. It records when the escape witness was proposed, which information was available, which checks rejected alternatives and which artifact was frozen for acquisition. Fresh-task transfer and retention are measured after the contributor, search aid and temporary context are removed. The semantic discovery records provide the evidence slots; this convention adds the locality and path conditions needed to interpret a claimed change of idea basin.
Convention. Assays for transfer, remix and construction [ftip-00OU]AGENTDRAFTED
Convention. Assays for transfer, remix and construction [ftip-00OU]AGENTDRAFTED
A research campaign should expose separate outcomes before assigning a hull grade. The semantic discovery records supply the trace, and this convention supplies the corresponding fresh-task assays. Every arm fixes the task law, model versions, source corpus, reveal schedule, checker, interaction permissions and resource accounting before final evaluation.
- Retrieval and associative application. Reveal a target whose relevant source concept is in the permitted endowment. Measure whether the system selects and applies it, while charging search and interpretation.
- Transfer. Withhold the target construction and present a fresh problem or representation. Require a transfer map, a preserved relation and a checkable target result. New wording with the same mathematical structure is a limited transfer test; a new composition regime is a separate extrapolation assay.
- Remix. Hold out the joint composition of admitted source concepts. Require an explicit interface and a result that depends on the new dependency, then compare against each source concept alone and against irrelevant material of similar size.
- Construction. Hold out the target object or principle and expose a verified obstruction. Require a portable difficulty problem, a positive construction, an essential-resource account and at least one consequence beyond the motivating instance.
- Basin escape. Before research, declare the state descriptor, local move set, canonicalization, horizon and resource budget. Compare stateful continuation with fresh-context or harness-reconstructed variants at matched seeds and cumulative tokens. Record plateau, experiment diversity and score headroom; count escape only when a declared witness changes the representation, decomposition, invariant, objective or search operator and the resulting state passes independent checks on withheld or fresh tasks. A changed label or longer local search is not an escape; retain failed escape attempts and test the frozen artifact for transfer.
- Consequence and verification. Reveal fresh instances and adversarial counterexamples after the construction is frozen. Check certificates, proof obligations, failure cases and provenance with an evaluator independent of the proposing transcript.
- Acquisition. Remove the contributor, search aid and temporary context, freeze the retained artifact, and test a new recipient or fresh recipient instances under a common deployment budget. Report library, procedural, parameter and combined retention separately.
The campaign includes controlled rediscovery, withheld research and open research as distinct task regimes. A controlled case tests whether the system can reconstruct a known concept; a withheld case tests development without the published construction; an open case adds a historical-novelty question. A success in one regime does not establish success in another. Initial difficulty is measured under the declared admission procedure in Initial difficulty, discovery and retained capability, and costs and outcomes follow Costs, measurements and outcomes.
Report the profile fields and the evidence status independently. Do not collapse retrieval, transfer, remix, construction, consequence, verification and acquisition into one headline score. A failed lower-level assay limits the interpretation of a higher-level claim; a successful assisted result without retention remains an assisted-deployment result. These controls make the harness auditable while leaving the capability definitions in Conceptual transfer and constructive invention.
Definition. Initial difficulty, discovery and retained capability [ftip-00NR]AGENTDRAFTED
Definition. Initial difficulty, discovery and retained capability [ftip-00NR]AGENTDRAFTED
Fix an initial agent, its available mathematical material and tools, a correctness standard, and a budget for an initial attempt. A problem is initially unresolved by this agent when the declared attempt procedure returns no accepted solution. A family-level measurement reports the initial success rate and its sampling uncertainty. Failure under this procedure neither proves that the solution is absent from pretrained weights nor establishes failure under every affordable procedure.
This operational condition permits three settings. In controlled rediscovery, evaluators know a useful mathematical concept and withhold its explicit construction. In withheld research problems, evaluators possess proofs that the agent cannot retrieve through its permitted interfaces. In open mathematical research, a result may also be new to the community. The initial agent can have relevant background knowledge in all three. Novelty, correctness and improvement over initial ability are different measurements.
The First Proof second batch provides a concrete withheld-research protocol: human-proved research lemmas were evaluated before their proofs were published, with organizer-run agents, a time limit and expert assessment. Its released statements and logs are now public, so a new experiment must use fresh withheld material or state which reconstruction of earlier access is being tested. An agent's accepted alternative proof can be a substantive discovery even if the theorem has an existing human proof.
The research campaign has three observable products. A discovery is an accepted mathematical result or method obtained during development. An acquired artifact is the state retained for subsequent work: parameters, a checked library, an executable representation, a search procedure, or an explicitly specified combination. Transfer is the performance of that frozen artifact on new problems under a common deployment budget. A successful answer to the current problem alone does not establish transfer. Continuing to consult the contributor during evaluation changes the system being measured and must be a separate condition.
DreamProver (sections 3--5) illustrates how research produces a reusable library. Failed training goals are decomposed into helper results; a later phase clusters, generalizes, verifies and prunes candidate lemmas. Libraries are then evaluated on separate theorems. The learned lemmas may be well-known mathematics, and the retained artifact is available in context rather than necessarily encoded by a parameter update. This is evidence for a particular acquisition mechanism, with discovery and library-construction costs still relevant to a complete comparison.
ProofEvolve (section 5.6) separates two useful reuse experiments. Synthetic compositional families compare a growing library against resetting it. A separate held-out theorem study supplies relevant self-generated, verified proofs as examples and compares them with no examples and random retrieval. That second experiment disables proof-graph search, decomposition and repair, so its measured gain isolates contextual reuse rather than the entire evolving prover. This suggests testing the contribution of an acquired library independently of changes to the surrounding search algorithm.
The multi-agent concept-discovery study provides a complementary mechanism. A conjecturing process guides symbolic regression, a skeptical process challenges regularities by reweighting examples, and provability feedback helps select candidates. Experiments reconstruct expressions related to Euler characteristic and Betti numbers. The provided incidence matrices, dimensions, ranks and nullities already encode mathematical insight. Discovering an expression from those features and inventing the underlying representation are distinct acquisition tasks. A concrete experiment must state which one it measures.
SOAR makes useful teaching an executable development process: a teacher proposes intermediate exercises and is rewarded by measured student progress on difficult training questions. Its initial filtering by repeated failed attempts is an operational criterion, not an impossibility claim. Teacher development and recipient training are separately charged, including unsuccessful curricula. A contributor can therefore be a learned mathematical teacher rather than an unexplained source of ideal hints.
The autonomous comparator must also admit learning during search. TTT-Discover (section 3) updates a model while seeking an excellent solution to the current problem; later generalization is outside that stated objective. ThetaEvolve (section 4.3.1) includes an experiment freezing a checkpoint trained on one mathematical search task and applying it to unseen tasks. These mechanisms distinguish current search progress from retained parameter acquisition. Checkpoint selection and learning costs accompany the latter comparison.
The proposed FTIP experiment combines concept testing, verified lemma accumulation and recipient transfer. This combination is a research proposal, not a result reported jointly by the cited papers. Both campaigns retain the fixed mathematical rules and checker of § [ftip-00ML]; an external contribution may provide a representation, connection or curriculum developed from permitted related experience. Its producer does not receive the withheld evaluation answers. The recipient may reject it, improve it or find an alternative. All of that work belongs to the process being compared.
The finite comparison can show that one developed artifact is useful or affordable relative to tested alternatives. It cannot establish the all-lineage lower bound in Conjecture [ftip-00MN]. If an admitted classical solver, a self-generated library or a learned autonomous procedure reaches the same capability more cheaply, that finding is evidence against the proposed advantage for this setting. The correctness criterion does not privilege reconstruction of the evaluator's preferred concept.
Example. A finite setting for invariant rediscovery [ftip-00NS]AGENTDRAFTED
Example. A finite setting for invariant rediscovery [ftip-00NS]AGENTDRAFTED
A first concrete family can use linear chain complexes over the two-element field \(\mathbb F_2\). This adapts the incidence-matrix concept-discovery setting of Aggarwal et al. into an exact finite experiment. The chosen field, transformations and certificate tasks below are part of this proposal, not a reproduction of that paper.
An object consists of vector spaces of dimensions \(n_0,n_1,n_2\) and matrices \(D_1:\mathbb F_2^{n_1}\to \mathbb F_2^{n_0}\) and \(D_2:\mathbb F_2^{n_2}\to \mathbb F_2^{n_1}\) satisfying \(D_1D_2=0\). All entries, dimensions and allowed operations are public. Arithmetic is exact. Zero-dimensional spaces and zero maps are included. The experiment can provide only matrices and arithmetic, or additionally ranks and nullities; these are different initial endowments and receive separate results. Neither regime establishes discovery of the entire mathematical representation from unstructured observations.
The middle cycles and boundaries are \(Z_1=\ker D_1\) and \(B_1=\operatorname {im}D_2\). The chain identity gives \(B_1\subseteq Z_1\), so the quotient \(H_1=Z_1/B_1\) is defined. Rank-nullity yields
\[ \beta _1=\dim H_1 =n_1-\operatorname {rank}D_1-\operatorname {rank}D_2. \notag\]Indeed, \(\dim Z_1=n_1-\operatorname {rank}D_1\) and \(\dim B_1=\operatorname {rank}D_2\); taking the quotient subtracts these dimensions. At the ends, \(\beta _0=n_0-\operatorname {rank}D_1\) and \(\beta _2=n_2-\operatorname {rank}D_2\). These elementary identities explain the evaluator's target and remain withheld as explicit answers where rediscovery is being measured. They are not new mathematical results.
Allowed changes include invertible changes of basis \(P_i\) in each space. They replace the matrices by
\[ \begin {aligned} D'_1&=P_0D_1P_1^{-1},\\ D'_2&=P_1D_2P_2^{-1}. \end {aligned} \notag\]The product remains zero and the ranks remain unchanged. Another allowed change adjoins or removes a direct summand consisting of an identity map between two adjacent one-dimensional spaces, with zero maps elsewhere. That summand has zero homology in every degree. Direct sums add dimensions of homology, so these moves preserve all three \(\beta _i\). A candidate invariant can be challenged with new valid objects, basis changes and such elementary additions.
A target asks whether two presented objects are related by a sequence of these allowed moves. A positive certificate lists legal moves and their exact matrices, including inverses for basis changes and the displayed summand for a removal. A negative certificate supplies unequal homology dimensions with checked rank witnesses. A rank witness can give invertible row and column transformations, their inverses and a diagonal normal form with an identity block and zeros elsewhere; the checker verifies these matrix identities and counts the block size. Agreement of a proposed invariant on a few examples is insufficient, and equality of the dimensions alone is not accepted as a positive certificate. The agent must construct the required transformation or another certificate justified by the fixed mathematical checker.
A concrete sampler first draws uniformly from the finite set of nonnegative integer tuples \((h_0,h_1,h_2,r_1,r_2)\) satisfying the declared dimension cap, where
\[ \begin {aligned} n_0&=h_0+r_1,\\ n_1&=h_1+r_1+r_2,\\ n_2&=h_2+r_2. \end {aligned} \notag\]It builds a direct sum of zero-differential spaces of dimensions \(h_i\) in degree \(i\), \(r_1\) identity pairs in degrees one and zero, and \(r_2\) identity pairs in degrees two and one. Independently sampled invertible binary basis matrices scramble this presentation; uniform sampling by rejection from all binary square matrices is one exact choice. The resulting \(\beta _i=h_i\) are evaluator facts, not additional observations supplied to either agent. The distribution and sampling algorithm themselves are public, so reconstructing this decomposition is an admitted strategy.
Positive instances apply a sampled legal move sequence to an object, retaining that sequence privately. At each step the sampler chooses uniformly among the declared finite encodings of dimension-bounded legal moves; the identity move permits padding to the specified length. Negative instances draw two canonical tuples with different homology vectors and randomize their presentations independently. Their dimensions are matched where the chosen profile permits, and results are also stratified by dimension differences to detect easy size cues. Retained rank witnesses certify the labels. The mixture, move count, dimension profile and certificate limits are fixed before final seeds are sampled.
A single middle invariant is not complete even for this family. Objects concentrated in degree zero can have identical \(\beta _1=0\) and different \(\beta _0\), and hence cannot be related by the allowed moves. This provides a concrete counterexample to premature abstraction. A learner may retain the whole homology vector, refine its proposal or use direct algebraic reasoning; successful certification, rather than one preferred formula, determines the outcome.
This initial family has an efficient classical alternative. Gaussian elimination computes bases for cycles and boundaries and decomposes a finite complex over a field into homology summands and adjacent identity summands. It therefore supplies both the invariants and constructive transformations when appropriate. Its arithmetic and certificate costs must be measured as an admitted baseline. The setting can reveal how an agent develops and transfers a method, but cannot support a claim that all autonomous methods face a prohibitive search barrier merely because one language model initially fails it.
Convention. Developing a method and teaching a recipient [ftip-00NT]AGENTDRAFTED
Convention. Developing a method and teaching a recipient [ftip-00NT]AGENTDRAFTED
The finite family in Example [ftip-00NS] permits a complete account of what a contributor learns and what a recipient acquires. Development takes place on earlier instances with independently sampled seeds. The final instance distribution, allowed observations and resource caps are specified before development; target instances and their certificates remain unrevealed. Broad mathematical preparation is disclosed separately from work performed during this experiment.
An autonomous research process alternates candidate generation, experiments and proof attempts. It can propose expressions involving the available matrix features, search for transformations, generate helper lemmas or invent code. A skeptical process selects valid chains that challenge a proposal. Exact counterexamples return a failed instance; a finite test pass only advances a conjecture to a proof attempt. A general lemma enters the verified library only after justification in the fixed proof system. Special-case facts carry their assumptions and are not silently promoted to universal laws.
The library-development loop follows the mechanism of DreamProver: use failed goals to identify helper results, group related discoveries, propose generalizations, verify them and discard redundant material. Suitable discoveries here include behavior under direct sums, invariance under changes of basis, and the need to account for all relevant degrees. Generalization may fail; its attempts, counterexamples and proof costs are part of development. No rule confines the process to discovering the evaluator's homology formula if another certified method is useful.
One executable contributor begins with related finite linear-algebra episodes: solving systems, studying kernels and images, and comparing quotients of nested subspaces. A bounded learner selects useful exercises and retains procedures and justified claims. It subsequently encounters the chain-complex development family and can propose a connection, a proof-producing solver, or exercises that teach the connection to the recipient. Its prior lessons, their solutions and its development work are recorded. It does not receive final target answers, an ideal hint for each instance, or an uncharged completed representation.
A second contribution type is a learned teaching curriculum. Following the progress-based idea in SOAR, a teacher chooses intermediate tasks and is evaluated by improvement of a provisional student on a separate development set. Teacher selection never uses final evaluation outcomes. Useful exercises need not solve the ultimate task directly. Producing and testing them, training provisional students and selecting a curriculum all consume resources. The recipient may receive incorrect suggestions, provided their verification and rejection are included rather than scored as free work.
Separate recipient conditions identify what was acquired. A library condition retains checked statements, proofs and an executable retriever. A procedural condition retains a certified transformation algorithm. A parameter condition updates a declared trainable model using the permitted development material. A combined condition retains an explicitly listed combination. These are different systems, not interchangeable evidence that the same capability has entered model weights. Imported proof macros must expand or be justified under the unchanged checker.
After acquisition, freeze the retained artifact, remove access to the contributor and reveal fresh instances. Measure accepted certificates under a common deployment budget. Test new random presentations within the development size range first, then a separately specified larger-size or composition regime. Success on one does not imply success on the other. A further assessment asks for general laws about direct sums and allowed transformations, with formal proof or independently assessed mathematical arguments as declared in advance. Benchmark prompts and theorem families are held out by mathematical content, not merely renamed variables.
The contributor may itself be an agent, a human or another bounded learning process. What matters is its endowment, development, transmitted artifact and the recipient's resulting capability. Supplying a previously published human proof is a legitimate retrieval condition, but its effect does not by itself demonstrate that a newly developed contributor discovered or taught the method. This distinction permits successful autonomous research to revise the proposed complementarity claim.
Convention. A prospective comparison of research campaigns [ftip-00NU]AGENTDRAFTED
Convention. A prospective comparison of research campaigns [ftip-00NU]AGENTDRAFTED
The purpose of the first experiment is to determine whether a developed mathematical contribution improves affordable retained capability in Example [ftip-00NS]. The family, algorithm interfaces, model versions, seed schedule, success threshold and resource profiles are fixed before the contribution conditions are compared. A task initially easy for the agent cannot demonstrate overcoming its initial difficulty; a task solved cheaply by an admitted classical method cannot demonstrate a general discovery barrier. Both are informative outcomes.
The assay convention for transfer, remix and construction makes these outcomes separately testable while preserving the fixed family, reveal schedule and resource controls below.
Information revealed by the generator, certificate interface, exposed checker code or accessible literature belongs to the initial endowment. If it supplies the homology formula, evaluate construction and reuse of a certifying method rather than rediscovery of that formula.
A proposed pilot uses four disjoint sources of instances: admission probes, development episodes, development validation and final evaluation. Admission tests the initial agent without adaptation on 32 probes at a fixed per-probe budget. An operational admission threshold is at most eight accepted certificates. This threshold is a declared experimental choice, not a theorem about the model. Report every admission result. If the chosen family fails this condition, retain the result as an easy-family finding; any revised family starts a new prospectively specified experiment. Do not search for a family on which the assisted condition has already won.
One concrete size profile gives development objects at most eight dimensions in each degree, with up to eight generating moves; final in-distribution instances use the same profile and new seeds. A separate extrapolation set permits dimensions and move counts up to sixteen. For dimension cap \(d\), allow at most \(8d+16\) transformation steps and \(64(d+1)^3\) binary matrix entries in a certificate; check dimensions, indices and invertibility explicitly. All conditions share these limits, and generation rejects instances whose retained certificates exceed them. The pilot evaluates 128 final instances per regime, balanced between positive and negative generation, across ten independent development seeds. These are proposed settings, to be costed before execution; they are not reported measurements.
Development validation may select a checkpoint, library or curriculum; its repeated use and all discarded candidates are charged. Final instances are revealed only after the retained artifact is frozen. A failed final result cannot be used to revise that artifact within the same evaluation. If another research generation uses those results, it receives a new final set and a separate generation label. Exact repeated instances are excluded. Fresh presentations with the same homology are intentional transfer tests, not independent discoveries. For general-lemma assessments, screen equivalent statements and trivial variable renamings across training and final sets.
The comparison includes the following complete procedures.
- An exact classical solver constructs certificates by elimination and decomposition, including all certificate production and checking.
- A fixed initial agent uses direct attempts and verification feedback, establishing the reference capability under the common deployment cap.
- An autonomous researcher develops lemmas, curricula, representations and executable solvers from permitted initial material. Its search can use experiments, counterexamples, retrieval, persistent archives and, where the selected model permits it, parameter updates.
- The same recipient acquires a contribution from the specified developmental producer, with producer preparation, validation and teaching included in the campaign resources.
- Retrieval of existing mathematical methods is measured separately, with the same declared library or literature access and charged search and integration.
Within these conditions, compare relevant and irrelevant material at similar context size, an acquired library with its removal, and a learned curriculum with a predetermined curriculum. A parameter-acquisition claim also compares against giving the same material in context without training. These controls answer different questions and need not all share one headline score. The stronger autonomous method may reconstruct the contributor's development process, and that reconstruction is admitted whenever its initial material and operations are available.
[novikov2025alphaevolve] motivates allowing invented algorithms and code; [yuksekgonul2026testtime] motivates updates during search; [wang2025thetaevolve] motivates frozen transfer. [tsoukalas2026advancing] and [adamczewski2026oeisopen] motivate comparing richer research machinery against a strong simple loop. These choices prevent the unaided condition from being defined as one deliberately weak sampling recipe. They still form a finite tested collection, not every admitted lineage in the theoretical conjecture.
The initial finite problem permits a later research extension. New withheld lemmas can assess proof development in the manner of [abouzaid2026firstproof]; longer campaigns can use archives and communication as in [chung2026autonomousdiscovery]. Problem selection can also be assessed prospectively, following the question posed by [zheng2026problem]. Such an extension receives its own mathematical standard and evaluation schedule. Success on the finite linear-algebra family does not establish success on research mathematics.
Definition. Costs, measurements and outcomes that would change the claim [ftip-00NV]AGENTDRAFTED
Definition. Costs, measurements and outcomes that would change the claim [ftip-00NV]AGENTDRAFTED
A campaign's resource record includes model inference, training, mathematical experiments, classical computation, retrieval, contribution production, communication, certificate generation and verification. It also includes failed attempts, discarded checkpoints and validation used to select a method. Model calls alone do not equalize systems using different models, context lengths or training procedures. Record accelerator time, CPU work, human time, money, memory and wall time separately before applying any declared scalar conversion.
The transfer, remix and construction assays in ftip-00OU report profile fields and retention conditions separately from these costs.
Let \(D_A\) denote development work for an autonomous process and \(D_C\) the contributor's charged development. Let \(T\) include transmission, recipient adaptation and validation. For a common deployment budget, write \(E_A(N)\) and \(E_C(N)\) for work on \(N\) fresh instances, including certification. A specified accounting convention then compares
\[ \begin {aligned} W_A(N)&=D_A+E_A(N),\\ W_C(N)&=D_C+T+E_C(N). \end {aligned} \notag\]The expression includes any autonomous reconstruction of contributor preparation in \(D_A\). Report inherited preparation and resources treated as sunk separately for both sides. A marginal-session saving does not establish a lifetime saving. If resources remain a vector, compare each component or state a Pareto relation; do not add human hours to accelerator operations without a conversion rule.
At equal task distributions and accepted-success requirements, reuse can amortize a contribution. Under the additional approximation of constant per-instance costs \(e_A\) and \(e_C\), with \(e_A>e_C\), the contributed method has lower total work precisely when
\[ N(e_A-e_C)>D_C+T-D_A. \notag\]This is an accounting consequence, not a prediction that the inequality holds. If the contributed method has lower success, comparisons must account for the additional work required to reach the same criterion. If its per-instance work is no better, amortization alone cannot erase a larger initial cost. Report failures at a cap as censored attempts; do not turn them into an infinite measured cost or a solved-instance ratio.
The primary acquisition measurement is the fraction of new instances with accepted certificates under the fixed deployment cap. Record it separately for the original distribution and extrapolation regime, along with certificate lengths, work and failures. Repeat complete development campaigns, rather than only decoding from one favorable learned library. Use common evaluation instances for paired comparisons and report variation across development seeds. Cost-to-threshold conclusions require uncertainty for both success and work and must name the procedures and budgets tested.
Additional measurements explain a result without replacing it: which verified lemmas are used in accepted proofs; whether a transformation method handles new presentations; whether the recipient still succeeds without contributor access; and whether a new recipient benefits from the same artifact. A proof differing textually from examples is not by itself evidence of conceptual novelty. Conversely, reuse of a short verified lemma can be a useful acquisition even when that lemma is familiar to mathematicians.
The literature motivates several testable predictions.
- Relevant verified lemmas should improve recipient performance more than similarly sized irrelevant examples, as suggested by the reuse studies in DreamProver and ProofEvolve. A missing difference would weaken the claimed library mechanism for this family.
- Challenging conjectures with counterexamples should expose the failure of incomplete invariants, including the middle-degree example in Example [ftip-00NS]. If a simple algebraic solver already gives equivalent performance at lower cost, this mechanism supplies no cost advantage.
- A useful curriculum should improve frozen-recipient performance beyond direct exposure to its material at the same accounted resources. If it merely helps while the teacher remains present, the result concerns assisted deployment rather than retained capability.
- Amortized savings, when present, should depend on reuse count and the deployment regime. Failure on larger compositions would restrict transfer even if the original-size evaluation improves.
A positive pilot would establish a bounded acquisition result for the specified procedures. An autonomous reconstruction at comparable cost would weaken a proposed developmental advantage; a cheap classical solver would defeat an all-method barrier for this family. Neither result decides whether a different mathematical research family admits the separation in Conjecture [ftip-00MN]. Moving to that stronger claim requires a new family and an argument covering all equally useful methods, including implicit representations and future model generations.
Conditional obstructions to conceptual discovery [ftip-00MO]AGENTDRAFTED
Conditional obstructions to conceptual discovery [ftip-00MO]AGENTDRAFTED
One possible lower-bound mechanism is a necessary structural event: every successful route must construct or acquire some adequate representation. The event must cover alternative proofs and structures learned implicitly in parameters. The elementary probability bound below becomes informative only when its necessity and uniform probability premises can be established from the admitted system.
Proposition. A necessary-event bound for an evolving lineage [ftip-00MP]AGENTDRAFTED
Proposition. A necessary-event bound for an evolving lineage [ftip-00MP]AGENTDRAFTED
Fix \(B\in \mathbb N\) charged elementary transitions and a \([0,1]\)-valued realized acquisition score \(Z\), including its evaluation randomness. Let \(G_t\) mean a specified necessary structural event has occurred by transition \(t\). Assume \(G_0\) is false, \(G_t\subseteq G_{t+1}\), and \(Z\leq \mathbf 1_{G_B}\) almost surely. For deterministic \(\epsilon _t\in [0,1]\), suppose that every admitted campaign and every permitted positive-probability history before \(G\) satisfy
\[ \Pr (G_t\mid \text {that history at }t-1)\leq \epsilon _t, \qquad t=1,\ldots ,B. \]For general history spaces use the corresponding conditional-kernel bound almost everywhere for each admitted campaign. Include histories after training and controller replacement. Stopped runs are padded by absorbing transitions. Then every admitted \(P\) satisfies
\[ Q_{\mathrm {acq}}(P)=\mathbb E Z \leq 1-\prod _{t=1}^B(1-\epsilon _t) \leq \min \{1,\sum _{t=1}^B\epsilon _t\}. \]
Proof.
Proof.
Conditional on not having reached \(G\) by \(t-1\), survival at the next transition has probability at least \(1-\epsilon _t\). Conditional expectation gives
\[ \Pr (G_t^c)\geq (1-\epsilon _t)\Pr (G_{t-1}^c). \]Induction from \(\Pr (G_0^c)=1\) gives the product bound. The union bound on first-entry events gives the sum bound, while probabilities are at most one. Taking expectations of \(Z\leq \mathbf 1_{G_B}\) proves the score bound. For \(B=0\), the empty product is one and the bound is zero.
If the premise holds with \(\epsilon _t=\epsilon (n)>0\) at every work budget, then \(B_{\mathrm {closed}}(n,\tau )\geq \frac {\tau }{\epsilon (n)}\) for integer work budgets. A bound measured for one fixed checkpoint does not supply this premise. If other routes can achieve positive score without \(G\), the domination assumption fails. Calling \(G\) simply “success” does not explain a discovery mechanism without an independent probability bound. Recognition and learning obstructions may require other arguments.
Finite work, permanent barriers, and enumeration [ftip-00MQ]AGENTDRAFTED
Finite work, permanent barriers, and enumeration [ftip-00MQ]AGENTDRAFTED
Work exceeding a realistic cap, divergence with instance size, and permanent unreachability of a fixed target differ. A permanent barrier needs closure under all admitted learning, program and architecture changes. Excluding the target from a set does not derive that closure. An assisted crossing must leave the invariant set while preserving the checker. Fair enumeration gives a countercheck.
Proposition. A permanent barrier requires transition closure [ftip-00MR]AGENTDRAFTED
Proposition. A permanent barrier requires transition closure [ftip-00MR]AGENTDRAFTED
Let \(\mathcal R\) be a measurable set of complete states. Suppose the initial state lies in \(\mathcal R\) almost surely, and every admitted transition from a permitted history ending in \(\mathcal R\) remains in \(\mathcal R\) with probability one. Suppose no successful terminal state lies in \(\mathcal R\). Then for every admitted campaign,
\[\Pr (T_{\mathrm {success}}<\infty )=0.\]
Proof.
Proof.
Induction and conditional expectation imply that the state lies in \(\mathcal R\) at each finite time with probability one. The countable union of the null events of leaving \(\mathcal R\) has probability zero. Success at finite time would require such a departure.
Proposition. Finite certificates defeat an unrestricted never-reachable claim [ftip-00MS]AGENTDRAFTED
Proposition. Finite certificates defeat an unrestricted never-reachable claim [ftip-00MS]AGENTDRAFTED
Fix a target with a finite accepted signed certificate under a decidable checker. If the baseline admits enumeration of all finite signed candidate strings over a finite alphabet in increasing length, checking each in finite time, then some admitted procedure discovers a certificate in finite total work.
Proof.
Proof.
A finite alphabet has finitely many strings no longer than the accepted certificate. Each preceding check terminates, so the sum of their finite execution costs and the successful check is finite.
This assumes enumeration and checking have the required memory and other resources as work grows; it does not override fixed hardware caps. It gives no useful realistic work bound and no fresh-task acquisition guarantee. Short compressed proofs may still be expensive to expand.
Independent restarted attempts of uniformly bounded cost with fixed success probability \(p>0\) have expected attempt count \(1/p\). Full token support alone does not establish restart access, termination or such a fixed probability for an adaptive lineage. Other processes can succeed almost surely with infinite expected time. Neither one slow process nor one failed search bounds all admitted alternatives.
For a bounded pretraining trajectory diagnostic, see semantic representation diagnostics. It records held-out probe crossings and their threshold, family, scale, and checkpoint sensitivity without treating representation evidence as causal or as a deployment result.
Where contemporary self-improvement meets conceptual discovery [ftip-00MZ]AGENTDRAFTED
Where contemporary self-improvement meets conceptual discovery [ftip-00MZ]AGENTDRAFTED
Recent work supplies mechanisms for finding and using new structure, as well as examples of improvements generated inside a model's own workflow. A paper's motivating problem often extends beyond the part its method repairs. That difference identifies something to investigate; it does not establish an obstruction to every possible repair. The following studies connect these mechanisms to the conceptual-discovery conjecture, using the indicated primary versions.
Remark. Background structure and realized complementarity [ftip-00N0]AGENTDRAFTED
Remark. Background structure and realized complementarity [ftip-00N0]AGENTDRAFTED
Hemmer and colleagues distinguish available complementarity from benefit actually realized by a human–AI team. They also distinguish differences in information from differences in capability, and choosing an individual's answer from producing an answer neither individual supplied alone. This motivates the separation between Definition [ftip-00MV] and Proposition [ftip-00MW]: a source can expose useful structure while the joint procedure fails to exploit it. Their decision-making experiments do not establish learning into successor models.
In Semantic knowledge guides innovation and drives cultural evolution, Yaman, Tian and Lindström combine an agent-based model with a 1,243-participant experiment. Meaningful item depictions let participants use semantic knowledge; abstract symbols obscure it while preserving combination rules. Semantic knowledge and social learning support cumulative innovation. The model gives a concrete mechanism: learned representations direct exploration, and socially transmitted examples improve those representations across generations. The evidence comes from a closed-world recipe task. The authors also warn that strong priors may hide counterintuitive combinations. Cultural background is therefore a possible source of directed search, with relevance and flexibility still to be established.
Unlocking LLM Creativity in Science through Analogical Reasoning makes cross-domain object and relation mappings explicit, then searches for candidate solutions. It reports diversity and judged-novelty gains and four biomedical implementation case studies. Its cross-domain baseline also uses two model calls; its unconstrained baseline uses one. These counts help interpret the comparison without establishing matched total cost. Feasibility and later acquisition remain separate questions. Because the model itself constructs analogies, this method also belongs among the closed lineage's possible substitutes for an external contributor.
A testable hypothesis is that assistance helps when it supplies a relevant relation the recipient can verify more cheaply than it can discover. Compare a supplied relation with internally generated analogies at matched total cost. Give both arms the relevant background texts in a further comparison, charging retrieval and interpretation. If the advantage persists, access to texts alone has not explained it; if it disappears, this instance supports a background-access explanation. Neither outcome by itself bounds all admitted internal search procedures.
Remark. Choosing what is worth learning next [ftip-00N1]AGENTDRAFTED
Remark. Choosing what is worth learning next [ftip-00N1]AGENTDRAFTED
A contributor may offer a promising question or a direction of inquiry without knowing its final answer. The difficulty is prospective: the learner must choose where to spend effort before observing how much that effort will teach it. Surprise can prioritize noise, while measured learning progress arrives after the investment.
Herrmann and Schmidhuber model interestingness through complexity–runtime profiles and future compression progress under specified Length, Algorithmic and Speed priors. Their analysis and finite enumeration experiments study when present structure predicts further compressibility. Section 4.4 limits the formal correspondence through Busy Beaver time scales; a long plateau does not exclude a later breakthrough. The analysis supplies neither an affordable selector for frontier models nor a lower bound over their possible research strategies.
For the contribution model, a direction's quality needs an independent property: for example, a reduction exposing a learnable subproblem with bounded translation cost. Calling a direction “interesting” cannot supply that property for free. An informative experiment would compare equal-cost choices by the recipient, a contributor and a shuffled-direction control, then measure verified progress and fresh-task performance after a fixed learning budget. A plausible prediction is that a useful structural selector outperforms mere surprise when high-surprise distractors are present. A successful internal selector weakens the proposed external advantage for that specification.
Remark. Improving workflows and learning from comparisons [ftip-00N2]AGENTDRAFTED
Remark. Improving workflows and learning from comparisons [ftip-00N2]AGENTDRAFTED
Recursive Harness Self-Improvement addresses the cost of maintaining effective agent workflows and the need for useful execution traces in model–workflow co-evolution. It revises prompt-level workflows from pairwise evaluation history while holding the foundation model fixed. Experiments on 30 synthetic machine-learning research tasks show gains over the tested configurations. The proposed information-theoretic explanation is a hypothesis. Its conclusion leaves internalizing the resulting traces into future foundation models for future work. The improved workflow is evidence of better system behavior; successor-model acquisition needs a further result.
Mendel Gödel Machine diagnoses a different missed opportunity: editing from a single failed trajectory underuses comparisons across tasks and lineages. Its operators extract evidence from both kinds of comparison to edit agent scaffold code. The diagnostic theory assumes informative comparisons and an editor able to use them. Its simulations vary the comparative fixing advantage, including a null setting with no advantage, and its coding-agent experiments test bounded benchmark subsets. This is a concrete internal remedy, not evidence that every archive automatically yields useful structure.
These methods suggest an acquisition experiment with declared artifact types. First measure the improved workflow with its persistent instructions and memory. Then train a successor on the resulting traces and evaluate that frozen successor under the same declared deployment wrapper, with contributor access removed. An unchanged-weights comparison and a successor trained from baseline traces distinguish workflow effects from learning effects. All trace generation, evaluation, selection and training consume the lineage budget. A gain that survives the second comparison supports acquisition under that contract; a workflow-only gain still counts when workflows are among the allowed final artifacts in Definition [ftip-00MM].
A second prediction concerns archive quality: comparisons should help most when failures share an identifiable cause and the archive contains a relevant contrast. Vary those conditions while matching archive-building and editing costs. Successful internally generated comparisons must enter the closed baseline before attributing an affordable advantage to an external source.
Remark. Retained experience and the limits of self-imitation [ftip-00N3]AGENTDRAFTED
Remark. Retained experience and the limits of self-imitation [ftip-00N3]AGENTDRAFTED
Beyond Final Scores studies seven models on 36 long-horizon AI research and development tasks. Its process diagnostics separate framing, execution and feedback; its experience comparisons include continuations with retained versus erased experience and lessons transferred to held-out tasks. Reuse can help or mislead. Under its particular novelty review, three of 252 best-seed solutions qualify as novel approaches. This finite observation identifies a problem in the tested setting, without proving a ceiling over alternative learning lineages.
The mechanism worth testing is whether a learner can extract a reusable principle while discarding task-specific tactics. Compare raw experience, verified abstractions, deliberately mismatched lessons and no retained experience, with extraction and verification charged. Predict that matched abstractions help across the declared structural family and that harmful reuse increases when applicability conditions are violated. Improved internal experience revision is a possible remedy and belongs in the baseline.
Version differences matter for the stronger claim that a closed loop must deteriorate. The September revision of the RSI survey by Chen, Wang and Qu describes an unvanishing external-signal requirement. Zenil's August revision explicitly narrows that formulation: a per-generation correction fraction may vanish while cumulative correction remains sufficient. It distinguishes exact self-imitation, replacement, retention and correction, and does not assert universal collapse.
Zenil also distinguishes total information from the consequences an affordable procedure can make accessible. This is compatible with the role of computation in Definition [ftip-00MJ]: a new representation can expose a consequence without adding a hidden fact. Neither the information distinction nor the narrow resampling calculations show that an autonomous lineage lacks every useful representation change. A conceptual-discovery lower bound must constrain those alternatives explicitly.
Remark. Three obligations for a separation proof [ftip-00N4]AGENTDRAFTED
Remark. Three obligations for a separation proof [ftip-00N4]AGENTDRAFTED
The conditional transfer result separates three substantive obligations. First establish an affordably available contribution with independently meaningful structural quality. Then establish recipient interpretation, verification and acquisition within the remaining resources. Finally bound every admitted closed alternative, including internal analogy search, comparative archives, revised experience, task selection and changes across model generations. Existing studies motivate the first two and offer useful counterchecks to the third. They do not jointly prove the conjecture.
The central objective is to prove the separation. The developmental formulation in Remark [ftip-00N8] begins with absent experience and asks what family-specific argument makes every equally useful closed route expensive. An affordable qualified contributor and a recipient learning guarantee provide the constructive side; a necessary-event premise is insufficient unless its necessity and bound are derived for the admitted process.
Evidence can revise the setting while this proof is sought. A proved admitted procedure whose expected score exceeds the proposed ceiling invalidates that ceiling. One unusually successful run does not establish such an expectation, and failure of a tested menu does not establish a universal lower bound. Internal improvements belong in the closed process; a contribution the recipient cannot acquire leaves the constructive claim unproved. Fix the target, checker, endowments, resource limits and evaluation law before the decisive comparison.
The economic extension studies how civilization and economic reproduction constrain the resources available to these learning lineages. It separates feasible schedules from task-specific discovery difficulty.
Civilization, economic reproduction and capability [ftip-00NX]
📄PDFAGENTDRAFTED
- September 13, 2026
Civilization, economic reproduction and capability [ftip-00NX]
📄PDFAGENTDRAFTED
- September 13, 2026
Learning systems depend on productive capacity and on institutions that create, transmit and validate knowledge. Their training and deployment can change those conditions. This chapter extends the model-lineage framework by specifying economic trajectories alongside learning procedures. It studies the resources attainable before a deadline and the cost of acquiring contributions from a maintained knowledge-producing population.
An economic restriction and a computational difficulty are different premises. A resource envelope constrains what can be executed; a learning lower bound constrains what a task requires. A capability separation needs both, together with a realizable assisted procedure. The results below are conditional mathematical statements about specified models.
Economic conditions on a learning campaign [ftip-00NY]AGENTDRAFTED
Economic conditions on a learning campaign [ftip-00NY]AGENTDRAFTED
The architecture refinement makes a model implementation explicit when it affects a comparison. Economic conditions play an analogous role: they determine which resource schedules can be supplied, while the original checker, task law and acquisition criterion remain fixed.
Definition. Economic state and admissible joint execution [ftip-00NZ]AGENTDRAFTED
Definition. Economic state and admissible joint execution [ftip-00NZ]AGENTDRAFTED
Fix a horizon \(T>0\) and a lineage specification \(\Xi \). An economic specification \(\Omega \) consists of an initial state \(x_0\), causal transition laws, a class of policies, physical and financial constraints, and a measurable viability region \(\mathcal V\). A state may contain productive capital \(K\), maintained expertise \(H\), accessible knowledge \(D\), energy and hardware capacity \(E\), and institutional capacity \(J\). These coordinates name declared state variables; no production function or substitutability assumption follows from their names.
A joint execution \(z=(P,\pi ,x,r)\) comprises a permitted lineage procedure \(P\), a causal economic policy \(\pi \), its state trajectory \(x\), and an actual resource schedule \(r\). Transitions may depend on admitted learning outcomes and deployment decisions. Feasibility requires that \(r\) supplies every operation of \(P\) and every charged economic activity at the time and place used, under the hard resource conventions. All work on search, synthetic generation, evaluation and controller changes is included. Missing output scores zero. The procedure \(P\) includes the stopping and evaluation decisions induced by its resource schedule. Economic policies preserve the observation laws and information access permitted by \(\Xi \); they supply no undeclared channel for target answers.
Let \(\mathcal Z_{\rm phys}\) contain physically feasible joint executions. Financeable executions additionally satisfy specified balance sheets and funding constraints; viable executions also remain in \(\mathcal V\) almost surely. Thus
\[\mathcal Z_{\rm viable}\subseteq \mathcal Z_{\rm fin} \subseteq \mathcal Z_{\rm phys}.\]An equilibrium class is an additional restriction, not a synonym for all financeable choices. Welfare floors in \(\mathcal V\) impose normative or institutional constraints unless physical necessity independently justifies them. Autonomy may maintain schools, public knowledge and power infrastructure; its access to new target-specific contributions remains controlled by \(\Xi \).
Both arms disclose their endowments and use the same external accounting boundary. Currency outlays and physical resource coordinates remain separate. Buying electricity spends money and uses energy; these are two constraints on one transaction, not two independent monetary costs.
Definition. Economically conditioned potential [ftip-00O0]AGENTDRAFTED
Definition. Economically conditioned potential [ftip-00O0]AGENTDRAFTED
For any admitted class \(\mathcal Z\) of joint executions and acquisition score \(Q_{\rm acq}(P)\in [0,1]\), define
\[\Phi (\Xi ,\Omega ,T;\mathcal Z)= \sup _{z\in \mathcal Z}Q_{\rm acq}(P_z).\]Take the supremum of an empty class to be zero in the ordered interval \([0,1]\). For a nonnegative counted compute rate \(u_z\), define the hard resource envelope
\[\overline B(T;\mathcal Z)= \sup _{z\in \mathcal Z}\operatorname *{ess\,sup} \int _0^T u_z(t)\,dt,\]with zero for an empty class. The essential supremum is over the execution's declared randomness. A claim about expected expenditure alone does not bound this quantity. The compute unit is fixed by the operational semantics and must agree with any subsequent learning lower bound.
Class inclusion gives \(\Phi (\mathcal Z_1)\leq \Phi (\mathcal Z_2)\) and \(\overline B(\mathcal Z_1)\leq \overline B(\mathcal Z_2)\) whenever \(\mathcal Z_1\subseteq \mathcal Z_2\), with other arguments fixed. Indeed every value in the first supremum also occurs in the second. A supremum need not be attained: \(\Phi \geq \tau \) does not by itself provide a procedure with score at least \(\tau \).
Finite-horizon resources and discovery difficulty [ftip-00O1]AGENTDRAFTED
Finite-horizon resources and discovery difficulty [ftip-00O1]AGENTDRAFTED
Financing, hardware throughput and power supply constrain different coordinates of a learning schedule. Their uniform bounds can be combined without asserting that any bound is attainable. Infrastructure investment and algorithmic improvements belong among the policies being bounded.
Proposition. A uniform finite-horizon compute envelope [ftip-00O2]AGENTDRAFTED
Proposition. A uniform finite-horizon compute envelope [ftip-00O2]AGENTDRAFTED
Suppose for every \(z\in \mathcal Z\), almost surely, its nonnegative compute service rate \(u_z(t)\) has monetary price \(p_z(t)\geq p_*>0\), and
\[\int _0^T p_z(t)u_z(t)\,dt\leq F_T,\qquad u_z(t)\leq q(t),\qquad u_z(t)\leq e(t)P(t).\]The deterministic functions are measurable and nonnegative; \(0\leq F_T<\infty \), \(q\) and \(eP\) are integrable. Here \(q\) bounds usable hardware throughput, \(P\) available power, and \(e\) compute per unit energy. These bounds hold over all admitted investments, prices, implementations and efficiency changes. Then
\[\overline B(T;\mathcal Z)\leq \min \left \{F_T/p_*,\int _0^T q(t)\,dt, \int _0^T e(t)P(t)\,dt\right \}.\]
Proof.
Proof.
For each execution integrate the two rate inequalities. The expenditure inequality gives \(p_*\int _0^T u_z(t)\,dt\leq F_T\) almost surely. Taking the essential supremum for each execution and then the supremum over executions preserves all three bounds.
This is a necessary envelope. It does not establish that its minimum can be spent on an arbitrary schedule or that its inputs describe a particular economy. An excluded financing source or a permitted efficiency improvement that violates the displayed premises invalidates that application of the bound.
Proposition. Economic exclusion from an independent work lower bound [ftip-00O3]AGENTDRAFTED
Proposition. Economic exclusion from an independent work lower bound [ftip-00O3]AGENTDRAFTED
Fix \(0<\tau \leq 1\) and the autonomous procedure class admitted by \(\Xi \). Suppose every such procedure attaining \(Q_{\rm acq}\geq \tau \) requires a hard compute cap at least \(L>0\): no implementation with a smaller almost-sure cap attains that score. If a uniform economic envelope \(b\) satisfies \(\overline B(T;\mathcal Z_{\rm aut})\leq b<L\), then no admitted autonomous execution reaches score \(\tau \) by \(T\).
Proof.
Proof.
An admitted successful execution would implement an autonomous procedure with hard cap at most \(b<L\), contradicting the work lower bound.
An economically feasible separation additionally requires an actual assisted execution achieving the same score and satisfying the shared external constraints. The scalar relation \(U\leq b\) alone does not provide one: resource timing, memory, communication, contributor formation and evaluation must fit a supplied schedule.
The lower-bound premise must cover permitted representations, search, training and controller development. It is stronger than failure of a particular recipe. For the intended conceptual-discovery tasks, establishing such a lower bound remains part of the conjecture. The proposition makes a finite work lower bound operationally decisive when a separately justified economic envelope lies below it.
Knowledge reproduction and viable expenditure [ftip-00O4]AGENTDRAFTED
Knowledge reproduction and viable expenditure [ftip-00O4]AGENTDRAFTED
A learning campaign can divert resources from the productive knowledge stock that supports later learning. The following model gives a bound over all permitted allocations, including allocations that deliberately maintain that stock. It describes effective capacity to produce useful knowledge; copying a nonrival dataset does not consume its bytes. The distinction between use and access incentives is developed in Jones and Tonetti's economics of data.
Definition. A maintained productive knowledge stock [ftip-00O5]AGENTDRAFTED
Definition. A maintained productive knowledge stock [ftip-00O5]AGENTDRAFTED
Fix \(A,\eta ,\delta >0\) with \(g=\eta A-\delta >0\), and initial stock \(h_0\geq h_{\min }>0\). Productive output is \(Ah(t)\) per unit time, measured in a fixed consumption numeraire. Learning expenditure \(v(t)\) and maintenance \(m(t)\) exhaust output. Assume
\[v(t)+m(t)=Ah(t),\qquad \dot h(t)=\eta m(t)-\delta h(t)=gh(t)-\eta v(t).\]An allocation on \([0,T]\) is admissible when \(h\) is absolutely continuous, \(v\) is measurable, \(h(0)=h_0\), and almost everywhere \(0\leq v(t)\leq Ah(t)\), while \(h(t)\geq h_{\min }\) at every time. Randomized allocations must satisfy these conditions almost surely. The conversion \(\eta \) and depreciation \(\delta \) are model assumptions; no causal estimate of human deskilling is asserted.
The variable \(v\) measures expenditure, not compute. To connect it to \(u\) in the compute envelope, specify the service price and require \(p(t)u(t)\leq v(t)\). The model excludes other productive assets and outside output. Applications that admit them must enlarge its state and recompute the bound.
Proposition. A renewal bound valid for every admissible allocation [ftip-00O6]AGENTDRAFTED
Proposition. A renewal bound valid for every admissible allocation [ftip-00O6]AGENTDRAFTED
Every allocation in Definition [ftip-00O5] satisfies
\[\int _0^T v(t)\,dt\leq \min \left \{\frac {Ah_0(e^{gT}-1)}{g}, \frac {h_0e^{gT}-h_{\min }}{\eta }\right \}.\]
Proof.
Proof.
The stock equation gives \((e^{-gt}h(t))'=-\eta e^{-gt}v(t)\leq 0\) almost everywhere. Hence \(h(t)\leq h_0e^{gt}\). Integrating \(v\leq Ah\) gives the first bound. Integrating the discounted stock equation gives
\[\eta \int _0^T e^{-gt}v(t)\,dt =h_0-e^{-gT}h(T)\leq h_0-e^{-gT}h_{\min }.\]Since \(v\geq 0\) and \(e^{-gt}\geq e^{-gT}\), multiplication by \(e^{gT}\) gives the second bound. The argument is pathwise, so it also covers randomized causal allocations satisfying the hypotheses.
The bound is necessary and need not be attained. With a positive service-price lower bound \(p_*\), division by \(p_*\) supplies a compute envelope and can be used in Proposition [ftip-00O3]. The relevant autonomous lower bound is still independent of this stock calculation. The bound increases with \(T\); it makes no finite lifetime claim.
Financing as a constrained balance sheet [ftip-00O7]AGENTDRAFTED
Financing as a constrained balance sheet [ftip-00O7]AGENTDRAFTED
Expenditure must be financed even when hardware and power are physically available. Conversely, a fall in household income need not imply a fall in funds available for training. The following accounting model states exactly which funds enter the resource envelope.
Definition. A finite-horizon learning account [ftip-00O8]AGENTDRAFTED
Definition. A finite-horizon learning account [ftip-00O8]AGENTDRAFTED
Let \(b(t)\) be an absolutely continuous liquid balance with \(b(0)=b_0\geq 0\). Let \(f(t)\geq 0\) be admitted inflows, \(o(t)\geq 0\) other outlays, \(u(t)\geq 0\) the counted compute rate, and \(p(t)>0\) its price. Assume these flows are measurable and integrable, and the balance equation holds almost everywhere. The account satisfies
\[\dot b(t)=f(t)-p(t)u(t)-o(t),\qquad b(T)\geq 0.\]All quantities are measured over the same institutional boundary and time interval. Inflows include operating receipts, equity, grants and debt proceeds whenever admitted; debt service and terminal obligations enter outlays or a stronger terminal-balance condition. Receipts recycled within this account are not counted again as external funding. A restriction to retained earnings is a special financing model, not a property of AI.
For a resource envelope, require a uniform bound \(\int _0^T f(t)\,dt\leq F\) over the admitted policies, with \(0\leq F<\infty \). Expected inflows alone do not impose this almost-sure bound. Unlimited refinancing violates this premise unless some separate constraint bounds its cumulative proceeds.
Proposition. A compute bound from financed expenditure [ftip-00O9]AGENTDRAFTED
Proposition. A compute bound from financed expenditure [ftip-00O9]AGENTDRAFTED
If Definition [ftip-00O8] holds and \(p(t)\geq p_*>0\), then
\[\int _0^T u(t)\,dt\leq \frac {b_0+F}{p_*}.\]
Proof.
Proof.
Integration of the balance sheet gives
\[\int _0^T p(t)u(t)\,dt =b_0-b(T)+\int _0^T f(t)\,dt-\int _0^T o(t)\,dt \leq b_0+F.\]Apply the price lower bound. If the premises hold uniformly almost surely, the same bound holds for the hard envelope over all executions.
This establishes the financing term in Proposition [ftip-00O2] from an explicit account. It does not derive \(F\) from aggregate output or welfare. A concrete model must establish the inflow bound while admitting its actual investment, borrowing and redistribution mechanisms.
Competitive automation and retained training finance [ftip-00OA]AGENTDRAFTED
Competitive automation and retained training finance [ftip-00OA]AGENTDRAFTED
The AI Layoff Trap, Proposition 1, gives a static model in which firms internalize their own cost savings but only part of a demand loss. The calculation below reproduces its interior game and derives a conditional financing consequence. Cooperation here means maximizing joint firm profits; it is not a general social optimum. Appendix A of the paper leaves saving, investment and interest-rate closure outside the baseline model.
Definition. An interior automation game [ftip-00OB]AGENTDRAFTED
Definition. An interior automation game [ftip-00OB]AGENTDRAFTED
Fix an integer \(N>1\), \(L,k>0\), and \(0<\ell <s<k+\ell / N\). Firm \(i\) chooses \(\alpha _i\in [0,1]\), average automation is \(\bar \alpha =N^{-1}\sum _i\alpha _i\), and its profit is
\[\pi _i=\Pi _0+L\left (s\alpha _i-\ell \bar \alpha -\frac {k}{2}\alpha _i^2\right ).\]The saving \(s\) and demand leakage \(\ell \) are fixed parameters. In the seed model \(s=w-c\) and \(\ell =\lambda (1-\eta )w\), with wage \(w\), automation cost \(c\), spending propensity \(\lambda \) and replacement-income fraction \(\eta \). These are static parameters; they do not specify training expenditure or a law of economic development.
Strict concavity gives the unique Nash choice and the unique joint-profit maximizing choice, both interior:
\[\alpha ^{\rm NE}=\frac {s-\ell / N}{k},\qquad \alpha ^{\rm CO}=\frac {s-\ell }{k}.\]
Proof.
Proof.
Differentiate individual profit in \(\alpha _i\) to obtain \(L(s-\ell / N-k\alpha _i)\). Differentiate total profit in each choice to obtain \(L(s-\ell -k\alpha _i)\). The stated inequalities put both stationary choices strictly between zero and one; negative second derivatives establish the maxima.
Proposition. Retained-finance loss under the competitive allocation [ftip-00OC]AGENTDRAFTED
Proposition. Retained-finance loss under the competitive allocation [ftip-00OC]AGENTDRAFTED
In Definition [ftip-00OB], write total profit at a common choice \(a\) as \(\Pi (a)=N\Pi _0+NL((s-\ell )a-ka^2/2)\). Then
\[\Delta \Pi =\Pi (\alpha ^{\rm CO})-\Pi (\alpha ^{\rm NE}) =\frac {NLk}{2}(\alpha ^{\rm NE}-\alpha ^{\rm CO})^2>0.\]
Proof.
Proof.
Complete the square around \(a=(s-\ell )/k\). The difference of the choices is \(\ell (1-1/N)/k>0\).
Suppose both total profits are nonnegative, a fixed fraction \(\rho \in [0,1]\) funds the next training round, outside finance is unavailable, and its compute price is a fixed \(p>0\). The difference between the monetary training allocations is \(\rho \Delta \Pi \), and the difference between their financially purchasable compute quantities is \(\rho \Delta \Pi / p\). This follows directly from the stipulated rule \(C(a)=\rho \Pi (a)/p\); other physical constraints can prevent those quantities from being realized.
The result compares two allocations. It does not bound all autonomous policies, which may coordinate, borrow or maintain demand when permitted. For \(\rho =0\) the financing difference vanishes. Changing institutions or adding productive investment changes the model rather than contradicting the displayed algebra.
Distributed expertise and reliable acquisition [ftip-00OD]AGENTDRAFTED
Distributed expertise and reliable acquisition [ftip-00OD]AGENTDRAFTED
A maintained population can preserve distinct lines of experience and produce useful representations, criticism and proofs. The mathematical question is whether a recipient can find, validate and acquire useful structure at a lower total cost. Diversity alone supplies no probability bound. The following protocol strengthens the single-consultation result with explicit conditions for repeated acquisition.
Definition. Costed consultation with observable certification [ftip-00OE]AGENTDRAFTED
Definition. Costed consultation with observable certification [ftip-00OE]AGENTDRAFTED
Fix the shared task, checker, evaluation law and endowments from the lineage specification. Preparation of the contributor population and recipient costs at most \(S\geq 0\) in one declared additive resource unit. For a fixed integer \(k\geq 1\), a causal protocol makes at most \(k\) attempts, each with hard cost at most \(c\geq 0\). Each attempt includes selection of a contributor, communication, recipient learning, validation, and any reset. Retention, final selection and evaluation are also charged within these caps. All remaining resource coordinates require a feasible schedule.
An attempt either returns an observable certificate with a frozen recipient artifact or reports failure. The protocol returns the first certified artifact, continuing after each failure until certification or \(k\) failures; in the latter case it returns a declared fallback. Contributor access is removed for fresh evaluation. Let \(Z\in [0,1]\) be the resulting score. Assume \(0<q\leq 1\) and \(0<\beta \leq 1\) such that:
- At every prior failure history reached with positive probability, the conditional probability of certification on the next attempt is at least \(q\). For general history spaces this condition holds almost surely.
- For every possible selected certificate history, the conditional expected fresh-evaluation score of that retained artifact is at least \(\beta \), again almost surely.
The second premise is a soundness requirement for acquired capability, including any effect of selection. A proof checked on an observed task or a finite validation score need not imply it. Establishing such soundness, affordable contributor access and the first probability bound remains a substantive obligation for an application. Independent attempts are not required.
Proposition. A reliable acquisition bound [ftip-00OF]AGENTDRAFTED
Proposition. A reliable acquisition bound [ftip-00OF]AGENTDRAFTED
The protocol in Definition [ftip-00OE] has hard additive cost at most \(U=S+kc\) and attains
\[Q_{\rm acq}=\mathbb E Z\geq \beta \bigl (1-(1-q)^k\bigr ).\]
Proof.
Proof.
Let \(F_j\) denote failure of the first \(j\) attempts, with \(F_0\) certain. Conditional certification gives \(\Pr (F_j)\leq (1-q)\Pr (F_{j-1})\), hence \(\Pr (F_k)\leq (1-q)^k\). Conditional soundness at the first selected certificate and nonnegativity on failure imply \(\mathbb E Z\geq \beta \Pr (F_k^c)\). Summing the preparation and attempt caps proves the cost claim, including early stopping.
If \(0<q<1\) and \(0<\tau <\beta \), the choice
\[k=\left \lceil \frac {\log (1-\frac {\tau }{\beta })}{\log (1-q)}\right \rceil \]ensures \(Q_{\rm acq}\geq \tau \). If \(q=1\), one attempt suffices for \(\tau \leq \beta \). For example, \(q=1/4\), \(\beta =0.9\) and \(k=8\) give \(Q_{\rm acq}\geq 0.9(1-(3/4)^8)>0.8\); this is an illustration of the assumptions, not an empirical estimate.
Together with an actual economically viable schedule for this protocol and an independent autonomous hard-work lower bound \(L>U\), this supplies the assisted construction needed in Proposition [ftip-00O3], whenever the autonomous economic envelope is below \(L\). Here \(U\), \(L\) and that envelope must use the same counted resource unit, with any conversion explicitly justified. A low scalar cost does not establish the schedule or the lower bound.
Civilizational preparation and shared costs [ftip-00OG]AGENTDRAFTED
Civilizational preparation and shared costs [ftip-00OG]AGENTDRAFTED
A contributor population can serve many campaigns. Economies from sharing its preparation are meaningful only for an actual portfolio and under the same accounting treatment given to shared model pretraining. The following comparison makes the amortization and its quantifiers explicit.
Definition. A portfolio with charged preparation [ftip-00OH]AGENTDRAFTED
Definition. A portfolio with charged preparation [ftip-00OH]AGENTDRAFTED
For difficulty \(n\), fix \(R\geq 1\) specified tasks, their common evaluation convention and a portfolio success condition: each task's recipient attains expected fresh-task score at least \(\tau \). An admitted assisted construction pays preparation \(S(n)\) once and at most \(c(n)\) per task, including failed consultations and acquisition. Its actual joint schedule therefore has additive work at most
\[U_R(n)=S(n)+R c(n),\qquad \frac {U_R(n)}{R}=\frac {S(n)}{R}+c(n).\]This charges the whole preparation cost to the portfolio. A single campaign does not gain extra cash from anticipated future users. Count maintenance over the service interval and capacity needed for all tasks in \(S\) or \(c\); peak resources and time come from the actual schedule, not this sum.
Let \(L_R(n)>0\) be a lower bound on the total hard additive work of every admitted autonomous portfolio meeting the same success condition, including permitted shared training and development. One cannot obtain \(L_R\) by adding isolated-task lower bounds without proving that sharing does not invalidate the result. Marginal comparisons may disclose sunk preparation on both sides; lifecycle comparisons must charge both.
Proposition. A conditional asymptotic portfolio advantage [ftip-00OI]AGENTDRAFTED
Proposition. A conditional asymptotic portfolio advantage [ftip-00OI]AGENTDRAFTED
Under Definition [ftip-00OH], suppose actual assisted schedules exist and, for integers \(n\geq 1\), constants \(C_s,C_c,c_0>0\), exponents \(a,b,d\geq 0\) and \(r>0\),
\[S(n)\leq C_s n^a,\qquad c(n)\leq C_c n^b,\qquad R(n)=\lceil n^r\rceil ,\qquad L_{R(n)}(n)\geq R(n)c_0 n^d.\]If \(\max \{a-r,b\}<d\), then
\[\frac {U_{R(n)}(n)}{L_{R(n)}(n)}\longrightarrow 0.\]
Proof.
Proof.
Since \(R(n)\geq n^r\),
\[0\leq \frac {U_{R(n)}(n)}{L_{R(n)}(n)} \leq \frac {C_s}{c_0}n^{a-r-d} +\frac {C_c}{c_0}n^{b-d}\longrightarrow 0.\]For instance, \(a=2,b=0,r=2,d=1\) obeys the exponent condition. The displayed lower bound on autonomous portfolios is still a hypothesis; the calculation does not establish it for conceptual discovery. The result identifies a possible macroeconomic route: sustained expertise serves many tasks while each recipient acquires a comparatively inexpensive contribution. If autonomous preparation is equally reusable, the proposed \(L_R\) may fail.
Alternative mathematical models and failure conditions [ftip-00OJ]AGENTDRAFTED
Alternative mathematical models and failure conditions [ftip-00OJ]AGENTDRAFTED
Economic dependence does not fix the sign or magnitude of feedback. The models below isolate assumptions under which continued learning is sustainable, expertise is replenished or a machine can reconstruct the assisted process. Each is a mathematical alternative with stated premises, not a fitted description of the economy. The equations are elementary illustrations; links identify related research rather than attributing these particular equations to those papers.
Example. A maintained stock can finance training forever [ftip-00OK]AGENTDRAFTED
Example. A maintained stock can finance training forever [ftip-00OK]AGENTDRAFTED
In Definition [ftip-00O5], choose constant expenditure \(v(t)=gh_0/\eta \) and maintenance \(m(t)=\delta h_0/\eta \). Since \(g=\eta A-\delta >0\), these are nonnegative and sum to \(Ah_0\). The stock equation gives \(h(t)=h_0\geq h_{\min }\) for all \(t\geq 0\), so the allocation is admissible on every finite interval and
\[\int _0^T v(t)\,dt=\frac {gh_0}{\eta }T\longrightarrow \infty .\]At a fixed compute price \(p>0\), a service with constant physical capacity at least \(gh_0/(\eta p)\) can supply that positive compute rate indefinitely. Thus maintenance dependence and a finite bound for each deadline are compatible with infinite lifetime compute. No conclusion about unbounded capability follows without a learning model.
Example. Productive investment expands the envelope [ftip-00OL]AGENTDRAFTED
Example. Productive investment expands the envelope [ftip-00OL]AGENTDRAFTED
Consider a single productive capital stock \(K_0>0\), output \(AK\), depreciation \(\delta _K>0\) and allocation fractions \(s,\theta >0\) with \(s+\theta \leq 1\). Invest \(sAK\), spend \(\theta AK\) on training, and allocate the remainder to other uses. If \(A>0\) and \(\gamma =sA-\delta _K>0\), then
\[\dot K=\gamma K,\qquad K(t)=K_0e^{\gamma t},\qquad \int _0^T\theta AK(t)\,dt =\frac {\theta AK_0}{\gamma }(e^{\gamma T}-1).\]These identities follow by solving the linear stock equation and integrating output. With service price \(p>0\) and sufficient installed service capacity, division by \(p\) gives affordable compute. For \(T>0\), this expenditure exceeds the frozen-capital estimate \(\theta AK_0T\), since \(e^{\gamma T}-1>\gamma T\). That estimate cannot bound this policy. The model assumes investment converts into usable capital without delay; construction lags and essential complements require additional states.
Aghion, Jones and Jones study AI and economic growth with production and idea-generation mechanisms. Caballero analyzes a richer financing and capital-installation mechanism with alternative long-run outcomes. Neither citation makes the exponential path here an empirical forecast.
Example. Knowledge renewal depends on useful yield [ftip-00OM]AGENTDRAFTED
Example. Knowledge renewal depends on useful yield [ftip-00OM]AGENTDRAFTED
Let \(D(t)\) denote effective task-relevant coverage, rather than raw token count. Suppose useful new human input arrives at rate \(h\geq 0\), synthetic generation at rate \(v\geq 0\) has effective yield \(a\geq 0\), and coverage depreciates at rate \(\delta _D>0\). Under the stipulated law
\[\dot D=h+av-\delta _DD,\qquad D(t)=D_*+(D_0-D_*)e^{-\delta _Dt},\qquad D_*=(h+av)/\delta _D.\]Direct differentiation verifies the solution. For a required coverage \(D_{\min }>0\), if \(D_0\geq D_{\min }\) and \(h+av\geq \delta _DD_{\min }\), then \(D(t)\geq D_{\min }\) at every time. If \(h+av<\delta _DD_{\min }\) and \(D_0\) is finite, the path eventually falls below the threshold. The necessary synthetic contribution is exactly \(av\geq \max \{0,\delta _DD_{\min }-h\}\). Positive synthetic yield is necessary when human inflow leaves a deficit; an affordable schedule must also produce and check the generated material.
The scalar law omits distributional coverage and estimation error. The contrast between recursive replacement in Shumailov et al., accumulation in Gerstgrasser et al., and consistency conditions in Barzilai and Shamir is a reason to specify \(a\) and the learning process, not to assume that every generated token has fixed positive knowledge value.
Example. Essential and substitutable expertise give different restrictions [ftip-00ON]AGENTDRAFTED
Example. Essential and substitutable expertise give different restrictions [ftip-00ON]AGENTDRAFTED
Let \(H,M\geq 0\) denote usable human and machine expertise. Under perfect substitution, effective expertise is \(E=H+\chi M\) with \(\chi >0\). The productive requirement \(E\geq E_{\min }>0\) is satisfied with \(H=0\) whenever \(M\geq E_{\min }/\chi \). Under essential complementarity, take \(E=\min \{H,\chi M\}\) instead. Then \(E\geq E_{\min }\) implies \(H\geq E_{\min }\). Both claims follow directly from the definitions.
A human-stock floor can therefore represent either an explicit social constraint or an indispensable productive input. The latter interpretation requires a complementarity premise. An economic model does not prove biological exclusivity merely by naming one coordinate human expertise. The organization and substitution of knowledge also depend on communication and access, as modeled by Ide and Talamàs.
Example. Assistance can maintain or erode expertise [ftip-00OO]AGENTDRAFTED
Example. Assistance can maintain or erode expertise [ftip-00OO]AGENTDRAFTED
Fix maintenance \(m\geq 0\), assistance intensity \(a\geq 0\), and parameters \(\eta ,\delta _0>0\), \(\xi ,\delta _1\geq 0\). Consider
\[\dot H=\eta m+\xi a-(\delta _0+\delta _1a)H,\qquad H_* =\frac {\eta m+\xi a}{\delta _0+\delta _1a}.\]Here \(\xi a\) models learning produced by assistance and \(\delta _1aH\) models lost practice. The solution is \(H(t)=H_*+(H_0-H_*)e^{-(\delta _0+\delta _1a)t}\). If \(H_0\geq H_{\min }\), the stock stays above that floor for every \(t\geq 0\) exactly when \(H_*\geq H_{\min }\); if the stationary stock is smaller, it eventually crosses below. For a finite deadline \(T\), monotonicity instead makes viability equivalent to \(H(T)\geq H_{\min }\), which may hold even when the stationary stock is smaller. Moreover,
\[\frac {dH_*}{da}= \frac {\xi \delta _0-\delta _1\eta m}{(\delta _0+\delta _1a)^2}.\]Differentiation shows that the sign depends on the stated parameters. Neither automatic deskilling nor automatic skill improvement follows from assistance alone. Bastani et al. study learning outcomes under different assistance designs; their particular experiment does not identify universal coefficients for this stock law. Assistance and maintenance costs must also fit the resource account.
Proposition. Affordable autonomous reconstruction removes the gap [ftip-00OP]AGENTDRAFTED
Proposition. Affordable autonomous reconstruction removes the gap [ftip-00OP]AGENTDRAFTED
Fix one admitted assisted campaign with final score \(Z\in [0,1]\). Suppose an autonomous campaign is admitted under the same external resource caps and evaluation convention, with simulation, development and recipient learning fully charged. If its joint law of transcript, retained artifact and fresh evaluation agrees with that of the assisted campaign, then its expected acquisition score is identical.
Proof.
Proof.
The acquisition score is the expectation of the same bounded measurable score function under equal laws.
More generally, if these laws have total variation distance at most \(\varepsilon \), where \(\operatorname {TV}(P,Q)=\sup _A|P(A)-Q(A)|\), then \(|\mathbb E_PZ-\mathbb E_QZ|\leq \varepsilon \). Indeed, \(\mathbb E_PZ=\int _0^1P(Z>t)\,dt\), and the probability difference in each integrand is at most \(\varepsilon \). Thus the autonomous score is at least \(Q_{\rm acq}^{\rm assisted}-\varepsilon \).
Approximate agreement of output laws does not establish an almost-sure resource cap: admission of the autonomous implementation is a separate premise. Nor does computability establish affordable reconstruction of the contributor's development and observations. This is the economic version of the reconstruction boundary; a claimed separation must exclude such an affordable implementation by an actual lower bound.
Notes on formalizing counterexamples to Connes' rigidity conjecture [connes-0001]
📄PDFAGENTDRAFTED
- August 12, 2026
- Utensil Song
Notes on formalizing counterexamples to Connes' rigidity conjecture [connes-0001]
📄PDFAGENTDRAFTED
- August 12, 2026
- Utensil Song
These notes treat the OpenAI, Zhou, and Anthropic counterexamples to Connes' rigidity conjecture as three distinct formalization targets. All three proofs are in scope; the current detailed development follows Zhou's construction.
Introduction [connes-0010]AGENTDRAFTED
- with contributions from Utensil Song
Introduction [connes-0010]AGENTDRAFTED
- with contributions from Utensil Song
Connes' rigidity conjecture [connes-000O]AGENTDRAFTED
Connes' rigidity conjecture [connes-000O]AGENTDRAFTED
For a countable discrete group \(\Gamma \), the group von Neumann algebra \(L(\Gamma )\) is generated by the left regular representation of \(\Gamma \). When \(\Gamma \) has infinite conjugacy classes (ICC), meaning that every nonidentity conjugacy class is infinite, \(L(\Gamma )\) is a \(\mathrm {II}_1\) factor. The reconstruction question asks how much of \(\Gamma \) remains visible in that analytic completion.
Kazhdan's property (T) says that a unitary representation with almost invariant unit vectors has a nonzero invariant vector [ershov2010noncommutative, Section 3.1]. ICC makes the group von Neumann algebra a factor, while property (T) imposes representation-theoretic rigidity. These are the two hypotheses in the conjecture and in all three counterexample constructions below [zhou2026icc, Section 1, pp. 1–2].
Connes first proved that, for an ICC property-(T) group, \(\operatorname {Out}(L(\Gamma ))\) and the fundamental group \(\mathcal F(L(\Gamma ))\) are countable [zhou2026icc, Section 1, p. 1].
He subsequently proposed that such groups should be \(W^*\)-superrigid: for every countable group \(\Lambda \), an isomorphism \(L(\Lambda )\cong L(\Gamma )\) should force \(\Lambda \cong \Gamma \). Zhou's introduction states this original 1982 conjecture and distinguishes it from the later, narrower rigidity question for higher-rank lattices [zhou2026icc, Section 1, pp. 1–2].
The counterexamples considered here disprove the broad conjecture. They do not settle that higher-rank-lattice question.
Counterexample background [connes-000P]AGENTDRAFTED
Counterexample background [connes-000P]AGENTDRAFTED
The OpenAI and Zhou counterexamples were obtained independently and at nearly the same time. Zhou records that his preliminary manuscript predated the public OpenAI announcement, while acknowledging that the two projects were concurrent [zhou2026icc, Section 1, pp. 2–3].
OpenAI gives a countable family of pairwise nonisomorphic ICC property-(T) groups with isomorphic group factors [openai2026tenadvances, Chapter 4]. Zhou gives an explicit pair through a different action-changing construction [zhou2026icc, Theorem A and Section 3].
The later Anthropic proof gives another explicit pair by comparing a split extension with a nonsplit one [anthropic2026icc, Sections 3–5].
These are not three presentations of one proof. The algebraic datum hidden by the factor sits at a different level in each construction, and each factor argument removes it by a different measurable mechanism. The mathematical and formalization motivations for comparing them are stated next. The detailed OpenAI and Anthropic architectures appear in § [connes-000M] and § [connes-000N]; Sections 2–7 below follow Zhou's proof in its original order.
Motivation [connes-000Z]AGENTDRAFTED
Motivation [connes-000Z]AGENTDRAFTED
The motivation for this formalization experiment is threefold.
Mathematical motivation
Mathematical motivation
The three counterexamples form a controlled test of nonfaithfulness. OpenAI varies the abelian kernel [openai2026tenadvances, Chapter 4]; Zhou fixes the kernel while varying the action and module structure [zhou2026icc, Sections 1 and 3]; and Anthropic fixes both while varying the extension class [anthropic2026icc, Sections 3–5]. In each construction, a genuine group distinction survives algebraically but disappears after measurable crossed-product transport. The comparison asks which distinctions survive representation, twisting, duality, and analytic completion. Property (T) here serves as a control condition: failure of reconstruction persists for groups with strong representation-theoretic rigidity.
Formalization motivation
Formalization motivation
Formalization asks where the information is lost. Named interfaces for the characteristic-two retraction, Fourier shear, measurable transport, continuous closure, spectral detection, and characteristic-module obstruction turn the claim that a factor forgets structure into an auditable dependency map. This separates direct translation from designed bridges and makes the project a consumer of Mathlib and TauCeti. Missing or bespoke interfaces mark candidates for reusable contributions to those libraries.
Agent-assisted work and human examination
Agent-assisted work and human examination
The project also tests whether an agent-authored formalization can be brought to a standard suitable for human examination and digestion. Literature grounding, the exact external premise boundary, provenance, technical proof replay, mathematical audit, and companion notes answer different questions. Technical verification checks the formal statement and its replay; source and mathematical review ask whether the theorem, definitions, hypotheses, and supporting facts match the intended mathematics. A reader can then trace a claim from the literature to its Lean declaration, downstream use, audit status, and executable check.
Formalization design [connes-000K]AGENTDRAFTED
- August 12, 2026
- Utensil Song
Formalization design [connes-000K]AGENTDRAFTED
- August 12, 2026
- Utensil Song
The Lean development turns the preceding motivations into one construction stage and four certificate lanes: factor equivalence, property (T), ICC, and group nonisomorphism. The final theorem assembles those four endpoints.
The diagram is a map of both the proof and the notes. Solid arrows are internal Lean developments. The dashed arrow is the sole substantive mathematical input left external: the Ershov–Jaikin-Zapirain–Kassabov property-(T) theorem for \(\mathrm {EL}_3(\mathbb F_2[t])\). Each lane uses a separate port at the construction and theorem nodes.
The mathematical weight is uneven:
- Construction. The characteristic-two calculation in Lemma [connes-000C], with its Lean realization in § [connes-000U], is concrete algebra and supplies every later carrier.
- Factor equivalence. Theorem [connes-0007], § [connes-000D], and § [connes-000E] carry heavy operator algebra: compact duals, Haar measure, Fourier transforms, von Neumann closures, and trace transport.
- Property (T). Definition [connes-0003], § [connes-000V], Theorem [connes-0004], § [connes-000Y], Lemma [connes-0005], and § [connes-000W] carry heavy harmonic and representation theory. Spectral measures and finite detectors are internal; EJZK enters at one boundary.
- ICC. Theorem [connes-0006] is the lightest lane conceptually, but its implementation in § [connes-000X] still needs exact orbit and finite-quotient displacement calculations.
- Nonisomorphism. Theorem [connes-0008] is the deepest internal algebraic chain. Characteristic kernels, quotient twists, semisimplicity, and a finite cocycle obstruction must survive an arbitrary isomorphism.
Most definitions and algebraic laws translate directly. Six interfaces require special design:
- the square-span certificate implemented in § [connes-000U];
- the Fourier-shear proof of factor equivalence: its unitary implementation in Theorem [connes-0007], its automatic projection-order transport in § [connes-001C], the four conjugation identities in § [connes-001D], and the measure and closure arguments in § [connes-000D] and § [connes-000E];
- the quantitative detector and qualitative property-(T) boundary in Definition [connes-0003], § [connes-000V], Theorem [connes-0004], and § [connes-000Y];
- the three-case ICC criterion in Theorem [connes-0006] and § [connes-000X];
- the quotient twist in § [connes-000H]; and
- the proposition-valued assembly in § [connes-0002].
The formalization lessons are discussed in § [connes-000A], § [connes-000F], § [connes-001C], § [connes-001D], and § [connes-000J].
The code has two layers. Reusable group theory, linear algebra, topology, measure theory, and operator algebra live in a foundation layer. Zhou-specific carriers and certificates live in construction and paper layers. This separation lets the paper-facing modules state small consumer interfaces while coordinate or finite calculations remain behind named certificates.
The public formalization plan and statement map give the complete module and declaration crosswalk.
Each lane exports the smallest object needed by its next consumer: a spatial witness, a qualitative property-(T) certificate, orbit and displacement data, or a twist-stable module obstruction.
Four corrections were mathematically decisive:
- replace identity-action scaffolds by Zhou's actions;
- make the ICC abstraction handle the finite \(\operatorname {Sp}_4(\mathbb F_2)\) factor;
- follow the quotient automorphism induced by a hypothetical group isomorphism; and
- tie the factor target to the Fourier shear and completed von Neumann closures.
The final interface remains proposition-valued. Its assembly and trust boundary are detailed in § [connes-0002] and Theorem [connes-0009]; the remaining EJZK work is scoped in § [connes-000B], § [connes-000G], and § [connes-000I]; the representation-universe boundary is recorded in § [connes-000L].
Section 1 separates the mathematical introduction, counterexample background, three motivations, and design. Sections 2–7 correspond respectively to Zhou's Sections 2–7; their headings record that correspondence without reusing Zhou's section number as the note title. Section 8 collects proof-engineering adaptations. The challenge and its verification role are described in § [connes-001M]; § [connes-0018] and § [connes-0019] compare the other two proof architectures; § [connes-001A] scopes the remaining EJZK formalization; and § [connes-001B] records the human–agent contribution and review workflow.
The formalization adapts selected public Lean proof blocks and organization
patterns from a
pinned openai/ten-proofs snapshot,
but does not import that repository. The project records declaration-level
adaptations in its public
port map;
the concrete Zhou carriers, corrected theorem boundaries, and final assembly
are local to this development.
Characteristic-two tensor kernel (Zhou §2) [connes-0011]AGENTDRAFTED
Characteristic-two tensor kernel (Zhou §2) [connes-0011]AGENTDRAFTED
Tensor retraction in characteristic two [connes-001E]AGENTDRAFTED
Tensor retraction in characteristic two [connes-001E]AGENTDRAFTED
Lemma. Characteristic-two tensor retraction [connes-000C]
L∃∀NAGENTDRAFTED
Lemma. Characteristic-two tensor retraction [connes-000C]
L∃∀NAGENTDRAFTED
Let \(k=\mathbb F_2\), \(A=k[t]^3\), and let \[C=(A\otimes _k A)^{\mathrm {Flip}}.\] The diagonal function \(\Delta (a)=a\otimes a\) lands in \(C\). Although \(\Delta \) is not a linear map, Zhou's characteristic-two calculation produces a surjective linear retraction \(\delta :C\to A\) satisfying \(\delta (\Delta (a))=a\) [zhou2026icc, Section 2, Lemma 2.1]. The retraction is equivariant for the diagonal \(\mathrm {SL}_3(k[t])\)-action.
Formalizing the characteristic-two retraction [connes-000U]
L∃∀NAGENTDRAFTED
Formalizing the characteristic-two retraction [connes-000U]
L∃∀NAGENTDRAFTED
The Lean carriers and diagonal for Lemma [connes-000C] are
The implementation fixes the standard polynomial and coordinate bases. It takes the coefficientwise Hadamard product on \(k[t]\), applies it in the three coordinates of \(A\), lifts the resulting bilinear map through the tensor product, and restricts it to \(C\). The Boolean identity \(x^2=x\) gives \(\delta (a\otimes a)=a\).
The basis-dependent formula implements a basis-free role: a linear left
inverse to the diagonal squares, equivariant for the diagonal
\(\mathrm {SL}_3(k[t])\)-action. Equivariance is not proved by expanding an
arbitrary fixed tensor. The submodule
The basis calculation in
SquareSpanData interface therefore hides the coordinates from later
sections. Consumers need only the spanning result, so a future basis-free
construction could replace the formula without changing the action or theorem
interfaces.
Factor equivalence by Fourier shear (Zhou §3) [connes-0012]AGENTDRAFTED
Factor equivalence by Fourier shear (Zhou §3) [connes-0012]AGENTDRAFTED
Spatial factor equivalence [connes-001F]AGENTDRAFTED
Spatial factor equivalence [connes-001F]AGENTDRAFTED
Theorem. Spatial implementation of the factor equivalence [connes-0007]
Theorem. Spatial implementation of the factor equivalence [connes-0007]
The group von Neumann algebra \(L(G)\) is represented on \(\ell ^2(G)\) as the von Neumann closure of the left regular operators. Its canonical trace is the vacuum coefficient at \(\delta _e\). Consequently a unitary \(U:\ell ^2(G)\simeq \ell ^2(H)\) gives the required tracial equivalence once two facts are proved: conjugation by \(U\) carries one closed operator algebra onto the other, and \(U\delta _e=\delta _e\).
These are precisely the fields of
The theorem
For Zhou's groups, the concrete unitary composes the two Fourier models with
the fiber shear. The measure-transport and von Neumann closure obligations are
separated in § [connes-000D] and § [connes-000E]. Together they construct
Nonadditive shear and measure transport [connes-000D]
L∃∀NAGENTDRAFTED
Nonadditive shear and measure transport [connes-000D]
L∃∀NAGENTDRAFTED
Proposition 3.2 proves that the fiber shear preserves Haar measure and strictly conjugates the two actions. Its quadratic correction is generally not additive, so Zhou's Remark 3.3 does not claim a compact-group automorphism. Proposition 3.4 uses only the resulting equivariant measure-space isomorphism after Fourier transform [zhou2026icc, Proposition 3.2, Remark 3.3, and Proposition 3.4].
The independent crossed-product discussion in [openai2026tenadvances, Chapter 4, Section 2.3, equation (2.1)] states the same abstract mechanism: group-law compatibility of the underlying compact spaces is not required.
The Lean boundary mirrors this distinction. The concrete
At the foundation layer,
A measurable equivariant isomorphism is mathematically sufficient for the abstract transport. The concrete homeomorphism is formally convenient because pullback preserves continuous coefficients. The proof uses that extra structure for the density bridge and forgets it at the measurable boundary, without falsely requiring an additive equivalence. The separate closure step is recorded in § [connes-000E].
Continuous coefficients and von Neumann closure [connes-000E]
L∃∀NAGENTDRAFTED
Continuous coefficients and von Neumann closure [connes-000E]
L∃∀NAGENTDRAFTED
Coordinate characters have norm-dense linear span in the continuous
functions by Stone–Weierstrass. Since continuous coefficients act continuously
as crossed-product multipliers, the generic continuous-coefficient closure theorem
Pullback along the homeomorphism then gives
The paper-facing proof applies the transport and closure bridges once to each action, then composes the Fourier models with the shear. This removes parallel action-one/action-two closure plumbing while preserving Zhou's Proposition 3.4 endpoint and section order. Mapping a convenient generating family remains an intermediate step; the consumer-facing contract is equivalence of membership in the completed von Neumann algebras.
Property (T) by spectral transfer (Zhou §4) [connes-0013]AGENTDRAFTED
Property (T) by spectral transfer (Zhou §4) [connes-0013]AGENTDRAFTED
Qualitative property (T) [connes-001G]AGENTDRAFTED
Qualitative property (T) [connes-001G]AGENTDRAFTED
Definition. Qualitative property (T) interface [connes-0003]
L∃∀NAGENTDRAFTED
Definition. Qualitative property (T) interface [connes-0003]
L∃∀NAGENTDRAFTED
Let \(G\) be a countable discrete group. A unitary representation \(\pi \) has almost-invariant unit vectors if every finite \(K\subset G\) and every \(\varepsilon >0\) admit a unit vector \(\xi \) satisfying \[\lVert \pi (g)\xi -\xi \rVert <\varepsilon \qquad (g\in K).\] The project defines property (T) by requiring every such representation to contain a nonzero invariant vector. Relative property (T) for a subgroup \(N\leq G\) requires every such representation to contain a nonzero vector fixed by \(N\).
Property-(T) transfer interface [connes-000V]
L∃∀NAGENTDRAFTED
Property-(T) transfer interface [connes-000V]
L∃∀NAGENTDRAFTED
The exact Lean boundary for Definition [connes-0003] uses
the almost-invariance and property-(T) predicates
The transfer argument uses the fixed subspace \(H^N\) of a normal subgroup
\(N\) and its orthogonal complement. Relative property (T) produces a nonzero
vector in \(H^N\); property (T) of the quotient then acts on \(H^N\). The
relative-and-quotient transfer theorem
A future EJZK development should use Kazhdan pairs, ratios, or spectral
gaps internally, then export
Spectral criterion for split abelian extensions [connes-001H]AGENTDRAFTED
Spectral criterion for split abelian extensions [connes-001H]AGENTDRAFTED
Theorem. Spectral bridge for split abelian extensions [connes-0004]
L∃∀NAGENTDRAFTED
Theorem. Spectral bridge for split abelian extensions [connes-0004]
L∃∀NAGENTDRAFTED
A split extension \(A\rtimes H\) with \(A\) abelian turns the restriction of a unitary representation to \(A\) into harmonic analysis on the Pontryagin dual \(\widehat A\). For a vector \(\xi \), a projection-valued spectral measure \(P\) yields the positive scalar measure \[\mu _\xi (B)=\langle P(B)\xi ,\xi \rangle .\] Its total mass is \(\lVert \xi \rVert ^2\); kernel displacement becomes the energy \(\int _{\widehat A}|\chi (a)-1|^2\,d\mu _\xi (\chi )\); and quotient-fixed vectors give invariant measures. A positive atom at the trivial character yields a nonzero invariant vector through its spectral projection.
Formalizing the spectral bridge [connes-000Y]
L∃∀NAGENTDRAFTED
Formalizing the spectral bridge [connes-000Y]
L∃∀NAGENTDRAFTED
The project records the group-theoretic data consumed by
Theorem [connes-0004] in
The scalar measure and displacement interfaces are formalized in
The direct consumer boundary is the following positive-atom estimate. If an invariant probability measure \(\mu \) satisfies \[c(1-\mu (\{1\}))\leq \sum _{a\in J}\int |\chi (a)-1|^2\,d\mu (\chi )\] for some \(c>0\), then sufficiently small displacement on the finite detector \(J\) forces \(\mu (\{1\})>0\).
Over \(\mathbb F_2\), characters take values through the two-element circle
subgroup. The local equivalence
Elementary generation of SL₃ [connes-001I]AGENTDRAFTED
Elementary generation of SL₃ [connes-001I]AGENTDRAFTED
Lemma. Elementary matrices and special linear transport [connes-0005]
L∃∀NAGENTDRAFTED
Lemma. Elementary matrices and special linear transport [connes-0005]
L∃∀NAGENTDRAFTED
Let \(R=\mathbb F_2[t]\). The subgroup \(\mathrm E_3(R)\) is generated by transvections \(I+rE_{ij}\) for \(i\ne j\). Zhou's Proposition 4.1 first uses Euclidean row reduction to identify it with \(\mathrm {SL}_3(R)\), then invokes the property-(T) theorem of [ershov2017rootgraded, Theorem 1.1 and Section 1.2]. The equality step is not part of the remaining external boundary.
Consequently the multiplicative equivalence
Formalizing elementary generation and transport [connes-000W]
L∃∀NAGENTDRAFTED
Formalizing elementary generation and transport [connes-000W]
L∃∀NAGENTDRAFTED
The formalization proves the equality used in Lemma [connes-0005] by
determinant-preserving row operations and Euclidean descent on polynomial
entries, culminating in
It then constructs
Rewriting subgroup equality into carrier equality would expose dependent coercions throughout Section 4. Keeping transport at one explicit equivalence also lets later finite-index and quotient arguments remain independent of the chosen presentation.
ICC by orbit displacement (Zhou §5) [connes-0014]AGENTDRAFTED
ICC by orbit displacement (Zhou §5) [connes-0014]AGENTDRAFTED
ICC criterion [connes-001J]AGENTDRAFTED
ICC criterion [connes-001J]AGENTDRAFTED
Theorem. Orbit and displacement criterion for ICC [connes-0006]
L∃∀NAGENTDRAFTED
Theorem. Orbit and displacement criterion for ICC [connes-0006]
L∃∀NAGENTDRAFTED
For a countable group, the ICC condition asks that every nonidentity conjugacy class be infinite. In a semidirect product \(N\rtimes (S\times Q)\), the proof can be separated from the concrete formulas by supplying two kinds of certificates:
- every nonidentity \(a\in N\) has an infinite \(S\)-orbit; and
- every nonidentity \(q\in Q\) admits \(a\in N\) whose displacement \(a(q\cdot a)^{-1}\) is nonidentity and has an infinite \(S\)-orbit.
The structure
- A nontrivial \(S\)-coordinate inherits an infinite conjugacy class from \(S\).
- A pure kernel element uses the first certificate.
- A surviving \(Q\)-coordinate reduces to the second certificate.
This organization follows the cases used in [zhou2026icc, Section 5] without building the concrete tensors into the reusable ICC theorem.
Formalizing the ICC criterion [connes-000X]
L∃∀NAGENTDRAFTED
Formalizing the ICC criterion [connes-000X]
L∃∀NAGENTDRAFTED
The paper-specific work behind Theorem [connes-0006] is confined to orbit
calculations in
ICCOrbits.lean.
Those calculations construct the action data and yield
The displacement certificate is the finite-quotient input. Conjugating an element with nontrivial \(Q\)-coordinate by a kernel element changes its kernel coordinate by \(a(q\cdot a)^{-1}\). Asking directly for an infinite family of conjugates would duplicate this algebra for each action. The certificate instead exposes the one displacement whose infinite \(S\)-orbit suffices.
Nonisomorphism by characteristic modules (Zhou §6) [connes-0015]AGENTDRAFTED
Nonisomorphism by characteristic modules (Zhou §6) [connes-0015]AGENTDRAFTED
Characteristic-module obstruction [connes-001K]AGENTDRAFTED
Characteristic-module obstruction [connes-001K]AGENTDRAFTED
Theorem. Characteristic modules detect nonisomorphism [connes-0008]
Theorem. Characteristic modules detect nonisomorphism [connes-0008]
The Section 6 invariant is semisimplicity of a module obtained from the characteristic abelian kernel. This is suitable for formal transport: a group isomorphism identifies the characteristic kernels, descends to an automorphism \(\sigma \) of the finite quotient, and induces a linear equivalence between the first quotient module and the second module with its action restricted along \(\sigma \). Semisimplicity is invariant under that linear equivalence.
The characteristic-kernel and quotient-twist boundaries used here are separated in § [connes-000H].
On the first side, explicit decomposition into simple summands culminates
in
On the second side, a nonsplit submodule obstruction is proved for every
quotient twist \(\sigma \). The bridge
The public contradiction is
Characteristic kernels and quotient-twisted transport [connes-000H]AGENTDRAFTED
Characteristic kernels and quotient-twisted transport [connes-000H]AGENTDRAFTED
The characteristic-kernel step maps an abelian normal subgroup to both factors of \(\mathrm {SL}_3(\mathbb F_2[t])\times \operatorname {Sp}_4(\mathbb F_2)\). It therefore needs two vanishing results:
- The polynomial-matrix argument
- The stronger finite result
The product
argument applying both inputs is
Design adaptation: twisting does not repair nonsplitting. Restriction along a group automorphism is an equivalence of module categories, with inverse given by restriction along the inverse automorphism. The formal proof nevertheless exports the exact twisted obstruction needed by the consumer, so no unproved categorical transport principle remains hidden at the final contradiction.
Theorem assembly and trust boundary (Zhou §7) [connes-0016]AGENTDRAFTED
Theorem assembly and trust boundary (Zhou §7) [connes-0016]AGENTDRAFTED
Exact external boundary [connes-0002]
L∃∀NAGENTDRAFTED
Exact external boundary [connes-0002]
L∃∀NAGENTDRAFTED
The public theorem is
EJZKInput.
All spectral, factor, ICC, and nonisomorphism certificates downstream of that parameter are constructed in the project. This is completeness for the load-bearing content of Zhou's Theorem A under the project's definitions, not a claim that every expository sentence of [zhou2026icc] has been encoded.
The dependency boundary is deliberately narrow:
The solution import graph contains no axiom, opaque declaration, sorry, or
admit. Lean's axiom report for Connes.theoremA contains only:
propext;Classical.choice; andQuot.sound.
These are the usual Lean foundations used by the imported library. The one
sorry in an independent Comparator challenge is outside the theorem's
import graph.
Theorem A [connes-001L]AGENTDRAFTED
Theorem A [connes-001L]AGENTDRAFTED
Theorem. Assembly of Theorem A [connes-0009]
Theorem. Assembly of Theorem A [connes-0009]
The final assembly has four independent certificate branches. The spectral
branch proves property (T) for both concrete groups from the EJZK input and
the internally constructed finite detectors. The other branches provide ICC,
the trace-preserving group-factor equivalence, and nonisomorphism. The theorem
The source-facing declaration
Kernel and source trust boundary. The precise external premise, axiom report, and meaning of completeness are recorded once in § [connes-0002].
Formalization adaptations [connes-0017]AGENTDRAFTED
Formalization adaptations [connes-0017]AGENTDRAFTED
Dependency placement and consumer boundaries [connes-000A]
L∃∀NAGENTDRAFTED
Dependency placement and consumer boundaries [connes-000A]
L∃∀NAGENTDRAFTED
Place instances at their mathematical source. The compact-dual topology, second-countability, and measurable-space instances belong beside the Pontryagin dual construction in Section 3, not at their first measure-theoretic use in Section 4. Likewise, the additive group instance for a representation module belongs at the module boundary in Section 6. Early placement makes Zhou's section order an acyclic dependency discipline instead of a directory convention.
Concrete examples are:
- the dual topology instances
- the Borel instances
- the representation-module carrier instance
Isolate certificates from structural theorems. The finite symplectic enumeration, concrete orbit witnesses, and detector estimates live in dedicated files. Their consumers see named propositions or small structures. This prevents an exhaustive certificate, coordinate calculation, or normalization choice from contaminating a generic transfer theorem.
Index shared structure by the action.
Zhou's two groups have the same abelian kernel and acting group, but different
actions [zhou2026icc, Sections 2–5]. Lean therefore defines their common
semidirect-product carrier through
Keep the bicommutant boundary visible.
The group von Neumann algebra in Zhou's factor comparison is the bicommutant
of the left regular operators [zhou2026icc, Section 3 and Proposition 3.4].
The definition StarSubalgebra.centralizer as a von Neumann algebra and applies
VonNeumannAlgebra.commutant for the outer commutant. This removes a
duplicated proof of the outer commutant's double-commutant condition; it does
not replace the bicommutant by a topological closure or change the mathematical
boundary.
State the direct consumer boundary. The external theorem is requested as property (T) of the elementary group, not as a stronger numerical constant. The factor bridge asks for a spatial unitary that maps completed algebras and the vacuum. The ICC bridge asks for orbit and displacement data. Each boundary contains exactly what its next theorem consumes, which makes hypothesis strength and reuse auditable.
Structure forgetting and equivalence reuse [connes-000F]
L∃∀NAGENTDRAFTED
Structure forgetting and equivalence reuse [connes-000F]
L∃∀NAGENTDRAFTED
The formalization uses the topology of the fiber shear at an intermediate step. It defines the shear as an equivariant measure-preserving homeomorphism because pullback must preserve continuous coefficients. Once this density argument is complete, the crossed-product theorem uses only the underlying equivariant measurable equivalence.
Zhou's shear need not be additive, so the Lean proof does not treat it as a compact-group automorphism. Continuity is retained for the density argument and then forgotten. This matches the two roles separated in [zhou2026icc, Proposition 3.2 and Remark 3.3].
A second lesson came from the reverse inclusion between the generated operator algebras. Mathlib's continuous pullback is already a star-algebra equivalence, so its surjectivity proves that inclusion without a separate involutivity calculation. Similarly, the inverse law for conjugation by a linear isometry equivalence replaces a pointwise operator calculation. In both cases, an equality that first looked computational follows from the inverse laws of an equivalence.
Normality of the factor isomorphism [connes-001C]
L∃∀NAGENTDRAFTED
Normality of the factor isomorphism [connes-001C]
L∃∀NAGENTDRAFTED
Zhou's Proposition 3.4 identifies the two group factors by combining Fourier transform with the fiber shear [zhou2026icc, Proposition 3.4]. The Lean development records two properties of the resulting star-algebra equivalence explicitly. Preservation of projection suprema in both directions follows automatically from the star-algebra equivalence between these concrete operator subalgebras, while preservation of the canonical trace is proved from the spatial unitary.
The definition
IsLUB.
For star subalgebras of bounded operators, the usual order on projections
is characterized by \(p\leq q\iff pq=p\). A star-algebra equivalence preserves
multiplication, so
This refactor leaves the definitions of projection supremum and normal star-algebra equivalence independent of bounded operators. The operator order appears only in the theorem that applies those definitions to the group factors in Theorem [connes-0007].
Four conjugation identities [connes-001D]AGENTDRAFTED
Four conjugation identities [connes-001D]AGENTDRAFTED
To identify the generated von Neumann algebras, Lean checks what each chosen unitary does to the regular-representation generators. There is one calculation for the abelian kernel and one for the acting group in each of Zhou's two group constructions, giving four identities in all.
For the first group, see the kernel
These calculations spell out a step summarized by the Fourier and crossed-product identifications in [zhou2026icc, Proposition 3.4]. They carry the generators through the Fubini equivalence for a semidirect product and then through the Fourier unitary.
Most explicit heartbeat settings disappeared during the later proof cleanup. These four declarations still require a larger elaboration limit because Lean must simplify nested equivalences and pointwise operator formulas. The limit controls elaboration time; it adds no mathematical assumption.
Proposition-valued final assembly [connes-000J]
Proposition-valued final assembly [connes-000J]
Keep final assembly proposition-valued.
Section 7 combines previously proved endpoints. It does not accept a broad
record containing the desired conclusion as a field. This “certificate
isolation” makes #print axioms meaningful and lets semantic review trace
each conjunct to the file where its mathematics occurs.
The nonisomorphism conjunct is stated directly as the absence of a multiplicative equivalence, \(\neg \operatorname {Nonempty}(\Gamma _1\simeq \Gamma _2)\), rather than through a project-local synonym. This is Lean's standard expression for the absence of a group isomorphism, so the result proved in Section 6 can be used directly.
The same assembly pattern applies when a linear paper proof crosses topology, analysis, finite computation, and algebraic transport: export small propositions from those layers, then combine them only at the theorem boundary.
Comparator challenge and auditability [connes-001M]AGENTDRAFTED
Comparator challenge and auditability [connes-001M]AGENTDRAFTED
The Comparator challenge is an independent statement file, not a second formalization of Zhou's proof. Its purpose is to make the theorem small enough that a reader familiar with the mathematics and Lean can inspect the definitions, compare them with Zhou's Sections 3–7, and check that the solution proves the same statement [zhou2026icc, Sections 3–7]. It therefore uses the following design criterion: define no more vocabulary than is needed to state Theorem A. General notions should come from Mathlib when its definitions have the required meaning; a genuinely general local construction is a candidate for upstreaming rather than permanent duplication. The self-contained challenge at the synchronized commit is the file to inspect. The declaration links below point to the mirrored solution-side declarations, which have the same public contracts and are rendered by doc-gen4.
The declarations in that file divide into four groups.
- Mathematical-domain foundation.
- Theorem-specific data.
The abbreviations \(\mathbb F_2\), \(\mathbb F_2[t]\), and
\(\mathrm {SL}_3(\mathbb F_2[t])\), together with their inferred countability
instances, fix the coefficient ring and ambient matrix group.
The
- Paper-shape adaptation and transport.
- Verification boundary.
The challenge imports Mathlib, not the solution, and leaves only the body of
Recent simplifications illustrate the design. The reindexing proof now
shares
Mathlib now supplies the conjugacy-class operation, the centralizer star
subalgebra, and the commutant of a von Neumann algebra. The challenge reuses
those APIs. In particular, StarSubalgebra.centralizer and then apply
VonNeumannAlgebra.commutant; no separate proof of the outer
commutant's double-commutant condition is needed.
The concrete elementary subgroup and explicit EJZK premise are theorem-specific and should remain near the challenge. The trace-preserving factor witness is local statement vocabulary chosen to match Theorem A; it should remain local unless Mathlib adopts the same contract. By contrast, an arbitrary-index \(\ell ^2\) reindexing linear isometry and a bundled left regular unitary representation are genuinely general and plausible Mathlib contributions: the present library has the ingredients but no direct API with these contracts. If those are upstreamed, the reindexing lemma and the two action-law proofs can disappear from the challenge. Without that library API, further proof compression would mainly conceal the chosen left-action convention rather than remove mathematics.
OpenAI proof architecture [connes-0018]AGENTDRAFTED
OpenAI proof architecture [connes-0018]AGENTDRAFTED
Changing the kernel while preserving the measured action [connes-000M]
L∃∀NAGENTDRAFTED
Changing the kernel while preserving the measured action [connes-000M]
L∃∀NAGENTDRAFTED
Chapter 4 of [openai2026tenadvances] constructs a countable family \(\Gamma _n=E_n\rtimes K\). The acting property-(T) group \(K\) is fixed, while the discrete abelian kernels \(E_n\) are dual to different compact group laws on one underlying probability space. Binary carry changes the compact group structure but not its Borel probability space or the relevant \(K\)-action.
Pontryagin duality therefore presents every group factor by the same measured crossed product \(L^\infty (X\times Y)\rtimes K\) [openai2026tenadvances, Chapter 4, Sections 2.3, 4, and 6.1–6.2].
The proof separates the information forgotten by the group-factor functor from the information retained by the abstract group. The common measured action gives isomorphic factors.
For the first pair, order-four torsion already distinguishes the groups. For the full family, the parameter \(n\) is recovered from an intrinsic finite-orbit subgroup of \(E_n[2]/2E_n\); finite-index embeddings simultaneously prove mutual commensurability [openai2026tenadvances, Chapter 4, Sections 5.1, 6.2, and 6.4–6.5].
The same chapter proves property (T) by a relative-property-(T) spectral estimate and a Boolean-polynomial support bound, rather than taking it only from a classical lattice theorem [openai2026tenadvances, Chapter 4, Sections 5.2–5.5].
This is not Zhou's deformation. Zhou keeps both the discrete kernel and the quotient fixed and changes the action; the quadratic shear then conjugates the two dual actions [zhou2026icc, Section 1, pp. 2–3]. Here the action on the underlying measured space is already common, while the compact group law, hence its discrete dual, changes.
The present Lean development formalizes Zhou's action-changing route. Its Fourier and crossed-product interfaces are conceptually reusable, but the shifted carry groups, the infinite family, and its finite-orbit invariant are not claims of the current formalization. This change of kernel is also what lets the OpenAI construction produce an infinite fiber, whereas Zhou's theorem selects one explicit pair.
The balance of proof weight is correspondingly different. Once the compact models are identified as the same measured \(K\)-space, the factor comparison is short. More of the work lies in constructing the shifted family, proving the initial relative-property-(T) estimate, and extracting an intrinsic invariant that distinguishes every parameter. Zhou instead puts substantial weight into the explicit action conjugacy and into transporting a module obstruction through an arbitrary group isomorphism.
Anthropic proof architecture [connes-0019]AGENTDRAFTED
Anthropic proof architecture [connes-0019]AGENTDRAFTED
Changing the extension class and measurably gauging it away [connes-000N]
L∃∀NAGENTDRAFTED
Changing the extension class and measurably gauging it away [connes-000N]
L∃∀NAGENTDRAFTED
The construction in [anthropic2026icc] fixes both the kernel \(A=\mathbb Z^4\) and quotient \(Q=\operatorname {Sp}_4(\mathbb Z)\). It compares the split semidirect product \(\Gamma _0=A\rtimes Q\) with an extension \(\Gamma _\tau \) defined by a nonzero two-torsion class \([\tau ]\in H^2(Q,A)\).
The algebraic difference lies neither in the kernel nor in the action, but in the extension cocycle. The class is obtained as a Bockstein of the theta-characteristic cocycle [anthropic2026icc, Sections 3.1–3.3].
After Fourier transform, the two group factors become an untwisted and a twisted crossed product over \(\mathbb T^4\). A Borel choice of representatives for \(\mathbb R^4/\mathbb Z^4\) produces an integral carry cocycle. The paper combines that carry with a quadratic refinement of the symplectic form to construct phases \(\Psi _g\); their coboundary is exactly the dual twist \(u_\tau \).
The resulting gauge is a trace-preserving isomorphism of the crossed products [anthropic2026icc, Sections 2.3 and 5.1–5.3, especially Theorems 5.1 and 5.2].
Nonisomorphism survives because \([\tau ]\ne 0\): one extension splits and the other does not [anthropic2026icc, Section 4]. The paper proves ICC directly and obtains property (T) from the classical \(\operatorname {Sp}_4(\mathbb Z)\) and relative-property-(T) input, followed by finite-index permanence [anthropic2026icc, Lemmas 3.7–3.8].
The constructions vary three different algebraic data:
- OpenAI changes the kernel through a different compact dual law;
- Zhou changes the action through a nonsplit module extension; and
- Anthropic changes the group-extension class in \(H^2\).
Their measurable repairs also differ: an already common measured action, an explicit conjugacy of actions, and a one-cochain that untwists a crossed-product two-cocycle. Remark 7.1 of [anthropic2026icc] describes the last point as a torsion class becoming measurably trivial on the connected dual while its branch defects are repaired by the quadratic carry terms.
Formalizing this proof would not be a small refactor of the Zhou development. The current factor-transport layer treats untwisted crossed products and strict action conjugacy. The Anthropic route would need:
- explicit group-extension cohomology;
- cocycle-twisted crossed products;
- Borel fundamental-domain representatives; and
- a verified measurable gauge.
Its property-(T) lane appears shorter than the current EJZK boundary, but its factor lane introduces new infrastructure. These claims are not included in the present Lean theorem.
EJZK formalization outlook [connes-001A]AGENTDRAFTED
EJZK formalization outlook [connes-001A]AGENTDRAFTED
EJZK route and effort estimate [connes-000B]
EJZK route and effort estimate [connes-000B]
The exact property-(T) input is classical and mathematically well established. The literature survey in [ershov2017rootgraded, Section 1.2, pp. 3–4] recalls that Kazhdan's 1967 theorem, together with subsequent work of Vaserstein, gives property (T) for \(G_\Phi (\mathbb F[t])=E_\Phi (\mathbb F[t])\) when \(\mathbb F\) is finite and \(\Phi \) is a reduced irreducible classical root system of rank at least two.
Taking \(\Phi =A_2\) and \(\mathbb F=\mathbb F_2\) yields the required \(E_{A_2}(\mathbb F_2[t])=\mathrm {EL}_3(\mathbb F_2[t])\) instance. The open boundary is therefore one of formalization completeness, not mathematical uncertainty.
The only remaining substantive premise is property (T) for \(\mathrm {EL}_3(\mathbb F_2[t])\). The route estimated below specializes the 2010 elementary-group theorem to \(R=\mathbb F_2[t]\) and \(n=3\). Its graph and six-root estimates are cited in the implementation layers below. The later root-graded treatment supplies broader supporting language.
Our central estimate remains 24–28 thousand new Lean lines; a wider plausible range is 18–35 thousand. That range is about \(0.8\)–\(1.5\) times the roughly 23,000 lines already in the project. We expect the proof search and engineering to require two to four times the effort of the present formalization.
This estimates one explicit, quantitative route that fits the present Lean interfaces; it is neither a measure of confidence in the theorem nor a lower bound for formalizing the classical route. The literature supports the route and its decomposition, not these LOC or effort figures.
The six implementation layers, with overlapping uncertainty ranges, are:
- quantitative Kazhdan subsets, constants, and relative ratios, with a bridge to the current qualitative predicate; our internal allocation is 2–3.5 thousand lines;
- the six additive root-subgroup embeddings and the direct \(A_2\) commutator relations; our internal allocation is 2–4 thousand. A Steinberg-group detour is optional, not required for this direct matrix-group specialization;
- fixed-space angles, codistance, and the class-two nilpotent estimate; our internal allocation is 5–9 thousand;
- the unweighted standard-Laplacian boundary case on six vertices. This is Section 5.4 of [ershov2010noncommutative]. Our internal allocation is 1.5–3 thousand; the weighted criterion in Section 5.5 is a separate generalization;
- the packaged relative-ratio estimate for the union of all six root subgroups in [ershov2010noncommutative, Proposition 6.1, p. 34]; our internal allocation is 3–5.5 thousand. Six repeated Lean instantiations would be an implementation choice, not six mathematical inputs; and
- assembly plus the exact qualitative export theorem for the elementary-group property-(T) boundary; our internal allocation is 1.5–3 thousand.
The allocations overlap. Their subtotal also excludes integration adapters, proof-search retries, and pin-specific repair risk, so it is not an arithmetic derivation of the 18–35 thousand-line envelope.
The existing analytic shell is not part of the missing estimate.
The remaining work is the quantitative root-subgroup, fixed-space, graph, and detector mathematics listed above; it should reuse that shell rather than construct another PVM layer.
Available Mathlib and TauCeti infrastructure [connes-000G]
L∃∀NAGENTDRAFTED
Available Mathlib and TauCeti infrastructure [connes-000G]
L∃∀NAGENTDRAFTED
The pinned Connes project uses Mathlib revision
c2d7843e
with Lean 4.34.0-rc2. Mathlib supplies the graph Laplacian and its positivity
theorem, exposed by the declaration links above, but not the
Ershov–Jaikin-Zapirain graph-of-groups criterion, Kazhdan ratios, root
gradings, codistance, or the graph argument.
Kassabov's estimates for a free associative integer ring require quotient transport before application to \(\mathbb F_2[t]\) [kassabov2005universal, Theorem 2.2 and Lemmas 2.3–2.7]. For an arbitrary finitely generated ring and module, the cleaner calibration is [ershov2017rootgraded, Appendix Theorem A.1]. The direct route is the earlier quantitative development [ershov2010noncommutative, Sections 2–6 and Appendix A].
TauCeti at revision
ac3bfb3
uses Mathlib ac1b4db
and Lean 4.34.0-rc1. Its
diagonal-dominance proof
consumes the same Mathlib Laplacian facts.
Its source and roadmap contain no direct property (T), Kazhdan, codistance, root-graded-group, or magic-graph lane. Recent algebraic-group root-space additions do not supply the root-graded-group criterion used by EJK. TauCeti is therefore not a drop-in dependency for this boundary; aligning project pins would not reduce the missing mathematics.
Alternative EJZK routes and literature anchors [connes-000I]
L∃∀NAGENTDRAFTED
Alternative EJZK routes and literature anchors [connes-000I]
L∃∀NAGENTDRAFTED
Bounded elementary generation is not presently shorter. Nica's [nica2019bounded, Theorem 2, p. 2] gives \[\nu _3=\frac {3\cdot 3^2-3}{2}+29=41,\] and its proof invokes the Kornblum–Artin theorem for irreducibles in polynomial arithmetic progressions, stated as [nica2019bounded, Theorem 3, p. 2]. That input is absent from the pinned Mathlib revision.
Our internal estimate for a self-contained Nica–Kassabov route is 20–45 thousand lines and three to six times the current engineering effort, with roughly 70 percent internal uncertainty.
Assuming Kornblum–Artin gives our internal estimate of 8–15 thousand lines, but merely moves the external boundary. Our internal estimate for a reusable formalization of the generic EJK theorem is 45–90 thousand lines; that generality is unnecessary for Zhou's application.
The route decomposition has four literature anchors:
- Zhou's exact invocation [zhou2026icc, Proposition 4.1, pp. 8–10];
- the elementary-group theorem, unweighted boundary graph, and packaged six-root estimate [ershov2010noncommutative, Theorem 1.1, p. 1; Section 5.4, pp. 25–29; Proposition 6.1, pp. 34–35];
- the broader root-graded theorem and arbitrary-ring relative estimate [ershov2017rootgraded, Theorem 1.1, p. 3; Appendix Theorem A.1, p. 110]; and
- Kassabov's free-associative-ring estimates and Nica's exact-ring alternative.
None states our LOC or effort ranges.
Representation-space universe boundary [connes-000L]
L∃∀NAGENTDRAFTED
Representation-space universe boundary [connes-000L]
L∃∀NAGENTDRAFTED
The cited literature formulates property (T) by quantifying over unitary representations. The basic definitions and elementary-group theorem appear in [ershov2010noncommutative, Section 3.1 and Theorem 1.1]; the root-graded generalization is [ershov2017rootgraded, Theorem 1.1]. Lean must also make the size of each carrier explicit.
The current
Type u and quantifies over Hilbert carriers in the same
Type u. This conventional interface is sufficient for the theorem
schema formalized here.
It matches the spectral consumer:
spectral_criterion_unconditional is uniform in each
K : Type u and each UnitaryRepresentation G K, rather than
selecting one concrete \(\ell ^2\) or regular representation.
The interface does not assert universe independence. A classical theorem
quantifying over carriers in every universe implies this predicate by
restriction to Type u; thus EJZK safely supplies the premise used here.
The converse is nontrivial and is not part of the present interface.
For a countable group, that converse has a two-stage route:
- Choose witnesses for every finite subset and a cofinal sequence of positive accuracies. The closed span of their group orbits is invariant, complete, separable, and still has almost-invariant unit vectors. An invariant vector there remains invariant in the original representation.
- Choose a countable Hilbert basis, reindex it by a small countable type, and conjugate the action onto the resulting \(\ell ^2\) carrier in the group's universe. The same-universe predicate then gives the polymorphic statement.
The pinned
Mathlib
already contains separability of spans
(TopologicalSpace.IsSeparable.span), separability of closures
(TopologicalSpace.IsSeparable.closure), completeness of closed spans
(Submodule.topologicalClosure.completeSpace),
and Hilbert-basis existence (exists_hilbertBasis).
At the pinned
TauCeti
revision, the continuous-representation library provides invariant restriction
(TauCeti.ContRepresentation.subrepresentation), unitarity
under restriction
(TauCeti.ContRepresentation.IsUnitary.subrepresentation), and
transport along an isometry
(TauCeti.ContRepresentation.IsUnitary.congr).
Its compact-group lane also standardizes finite-dimensional carriers
(TauCeti.IrrepModel) by an orthonormal basis, following the explicit
finite-dimensional universe convention
in its roadmap.
Neither pinned codebase assembles the countable invariant span, gives its Hilbert basis a small countable index, or transports the full property-(T) predicate across that model. Together these form the lowering seam.
They are more focused than generalizing the entire
Disclosure of AI use [connes-001B]AGENTDRAFTED
Disclosure of AI use [connes-001B]AGENTDRAFTED
Human direction and agent implementation [connes-000R]AGENTDRAFTED
Human direction and agent implementation [connes-000R]AGENTDRAFTED
This is a human-directed, substantially agent-implemented formalization and exposition project. The division of work was concrete.
Human mathematical and proof direction
- selected Zhou's theorem and required completion of every Zhou-internal argument, with property (T) for \(\mathrm {EL}_3(\mathbb F_2[t])\) as the single explicit external premise;
- fixed Zhou's Sections 2–7 as the proof order and required the overview to show one construction feeding factor equivalence, property (T), ICC, and nonisomorphism; and
- required comparison of the OpenAI, Zhou, and Anthropic proofs by the algebraic information each factor forgets, followed by the EJZK formalization outlook.
Human review and exposition contract
- required literature grounding, declaration-level provenance, public privacy boundaries, and Tau Ceti rubric review;
- required Linux Comparator verification with statement and axiom checks, confinement, Lean-kernel replay, and nanoda replay, while keeping technical acceptance distinct from mathematical audit;
- specified notes about the formalization rather than a restatement of the source papers, including proof architecture, mathematical weight, special designs, the threefold motivation, proof-family comparison, and unresolved boundaries; and
- reviewed rendered output and required corrections to headings, prose, diagrams, cross-references, navigation, privacy, and publication wording.
Human direction in recent refactoring
- requested repeated searches against the pinned Mathlib API, simplification of the challenge, and proof golf while preserving the exact theorem contract;
- treated heartbeat overrides as performance and refactor signals, required measured thresholds, and requested review of overlapping APIs and preparation of the Palomar metadata; and
- required the companion notes to track the Lean changes and identified
Agent implementation and review
- reconciled the literature and public Lean sources, adapted attributed proof blocks, implemented the Lean development, and refactored its public interfaces;
- implemented the resulting Mathlib reuse, action-indexed definitions, challenge and proof golf, measured heartbeat cleanup, and bicommutant simplification;
- ran full builds, Linux Comparator and nanoda checks, Lean-kernel replay, and clean-room reviews; reconciled the changes with the literature and public source; and repaired the resulting findings; and
- prepared the Palomar metadata and public documentation, then synchronized the mathematical notes, diagrams, comparisons, and formalization estimates under the human-specified structure and constraints.
The working cycle was: human proof and review contract \(\longrightarrow \) agent implementation \(\longrightarrow \) role-separated agent review and repair \(\longrightarrow \) human inspection and correction \(\longrightarrow \) approved landing.
Agent role separation is not independent human review; the project's audit ledger records the remaining review boundary. Public proof transfers are identified in the port map.
Notes on formalized Clifford algebra programme [fcap-0001]
📄PDFAGENTDRAFTED
- August 2, 2026
- Utensil Song
Notes on formalized Clifford algebra programme [fcap-0001]
📄PDFAGENTDRAFTED
- August 2, 2026
- Utensil Song
These are the accompanying mathematical notes for the experimental research project FCAP. FCAP is read “F-cap,” and studies whether Lean can serve both as a formal language for the abstract and concrete mathematics of Clifford algebras and as an implementation language for efficient symbolic and numerical computation. It is also a coined acronym for “Formalized Clifford Algebra Programme.”
FCAP's formalization is still at an early spike-test stage. The main storyline follows its own coordinate representations and orthogonal-product transport. The appendix is a mathematical companion to Tau Ceti's Clifford and Spin work: it connects the filtered exterior model, reflection and Pin/Spin constructions, bivector lifts, real signatures, and spinor modules. Those results supply context and possible tools for FCAP's longer program; the appendix does not claim they are FCAP formalizations.
Coordinate representations [fcap-0002]AGENTDRAFTED
Coordinate representations [fcap-0002]AGENTDRAFTED
A basis of the generating module gives coordinates on the exterior algebra, and the exterior equivalence transports those coordinates to the Clifford algebra. The empty and singleton coordinates fix the scalar and generator conventions. Orthogonality then controls how certain ordered products pass between the two algebras.
Definition. Transported exterior-basis coordinates [wieser2024formalizing, 9.3.5] [fcap-0003]AGENTDRAFTED
Definition. Transported exterior-basis coordinates [wieser2024formalizing, 9.3.5] [fcap-0003]AGENTDRAFTED
Let \(R\) be a commutative ring in which \(2\) is invertible, let \(M\) be an \(R\)-module, and choose a basis \(b\) indexed by a linearly ordered type. Write \(E_b(s)\) for the exterior-basis vector indexed by a finite subset \(s\). For a quadratic form \(Q\), the Mathlib linear equivalence CliffordAlgebra.equivExterior from \(\mathcal {C}\kern -2pt\ell (Q)\) to \(\bigwedge _R M\) gives a coordinate basis
\[B_{Q,b}(s) = \operatorname {equivExterior}(Q)^{-1}(E_b(s)).\]
This basis is transported through a linear equivalence. It does not say that the equivalence preserves multiplication or that Clifford multiplication becomes exterior multiplication. The basis-free construction is developed in [wieser2022formalizing].
The exterior equivalence is treated in [wieser2024formalizing, 9.3.5].
Two calculations anchor the choice. The empty subset maps to the scalar unit, \[B_{Q,b}(\varnothing ) = 1,\] and a singleton maps to the corresponding Clifford generator, \[B_{Q,b}(\{i\}) = \iota _Q(b(i)).\] These are module-level identities: they determine the first two coordinate types but do not determine multiplication of arbitrary coordinates.
For subsets with several elements, a coordinate formula additionally needs an ordering convention and its attendant signs. No such convention is implicit in the transported basis.
Lemma. Orthogonal pair transport [wieser2024formalizing, 8.4] [fcap-0004]AGENTDRAFTED
Lemma. Orthogonal pair transport [wieser2024formalizing, 8.4] [fcap-0004]AGENTDRAFTED
Let \(R\) be a commutative ring in which \(2\) is invertible, let \(M\) be an \(R\)-module, and let \(Q\) be a quadratic form on \(M\). Write \(T_Q\) for the linear equivalence from \(\mathcal {C}\kern -2pt\ell (Q)\) to the exterior algebra supplied by CliffordAlgebra.equivExterior. It is a module equivalence, not an algebra equivalence.
For vectors \(m,n \in M\), the change-of-form calculation for \(T_Q(\iota _Q(m)\iota _Q(n))\) has one extra scalar contribution, evaluated by the bilinear form associated to \(-Q\). If \(m\) and \(n\) are \(Q\)-orthogonal, that contribution vanishes. The resulting two-generator calculation is \[T_Q\bigl (\iota _Q(m)\iota _Q(n)\bigr )=\iota _0(m)\iota _0(n).\] This is the first point at which an orthogonality hypothesis changes the transport calculation. It does not turn \(T_Q\) into a multiplicative map.
The change-of-form construction is the relevant mathematical background in [wieser2024formalizing, 8.4], and the Lean construction of \(\operatorname {equivExterior}\) is described in [wieser2024formalizing, 9.3.5]. The concrete geometric-product discussion in [wieser2024formalizing, 2.1.2] motivates the role of orthogonality, but does not provide this note's formal interface.
Thus orthogonality removes precisely the scalar correction in the two-generator change-of-form identity. No basis or reordering convention is needed.
Lemma. Vanishing list contraction [wieser2024formalizing, 8.4, (8.54)] [fcap-0005]AGENTDRAFTED
Lemma. Vanishing list contraction [wieser2024formalizing, 8.4, (8.54)] [fcap-0005]AGENTDRAFTED
Let \(R\) be a commutative ring, \(M\) an \(R\)-module, \(Q\) a quadratic form on \(M\), and \(d : M \to R\) a linear functional. For a list \(l\) of generators, define an ordered product by \[P_Q([])=1, \qquad P_Q(m::l)=\iota _Q(m)P_Q(l),\] and write \(C_{Q,d}\) for left contraction by \(d\). The condition \(\forall m\in l,\ d(m)=0\) forces \(C_{Q,d}(P_Q(l))=0\).
There is one induction calculation. The empty product contracts to zero. At a head \(m\), the generator recurrence \[C_{Q,d}(P_Q(m::l))=d(m)P_Q(l)-\iota _Q(m)C_{Q,d}(P_Q(l))\] is the local rule in [wieser2024formalizing, 8.4, (8.54)]. The hypothesis deletes the first summand, and the induction hypothesis deletes the second. This turns the recurrence into a finite-list vanishing criterion rather than a calculation for one fixed product.
Only the ordered recurrence and pointwise vanishing of \(d\) matter; no basis or reordering convention is used.
Theorem. Pairwise orthogonal list transport [wieser2024formalizing, 8.4, (8.55)] [fcap-0006]AGENTDRAFTED
Theorem. Pairwise orthogonal list transport [wieser2024formalizing, 8.4, (8.55)] [fcap-0006]AGENTDRAFTED
Let \(R\) be a commutative ring in which \(2\) is invertible, let \(M\) be an \(R\)-module, and let \(Q\) be a quadratic form on \(M\). For a list \(l\) of vectors, write
\[P_Q([])=1, \qquad P_Q(m::l)=\iota _Q(m)P_Q(l),\]
and write \(T_Q\) for the linear equivalence CliffordAlgebra.equivExterior from \(\mathcal {C}\kern -2pt\ell (Q)\) to \(\bigwedge _R M\). In the corresponding zero-form product notation, suppose every earlier vector in \(l\) is \(Q\)-orthogonal to every later vector. Then
\[T_Q(P_Q(l))=P_0(l).\]
The order of the list is unchanged. The equality concerns this product under the stated orthogonality condition; it does not say that \(T_Q\) preserves arbitrary products.
The calculation proceeds from the head of the list. The one-generator change-of-form recurrence separates \(T_Q(P_Q(m::l))\) into the zero-form generator \(\iota _0(m)\) times the transported tail and a left-contraction correction. Pairwise orthogonality makes the associated dual vector vanish on every member of the tail. The criterion in Lemma [fcap-0005] therefore kills the correction, and the induction hypothesis transports the tail.
The contraction recurrence in [wieser2024formalizing, 8.4, (8.54)], the change-of-form recurrence in [wieser2024formalizing, 8.4, (8.55)], and the exterior equivalence in [wieser2024formalizing, 9.3.5] supply the local identities. Their induction over a pairwise-orthogonal list gives the displayed theorem; the source locations do not state that finite-list consequence separately.
The order of the list is fixed throughout. Reordering would require an additional permutation-sign calculation and is not a consequence of this theorem.
Theorem. Strict-inversion multiplication of orthogonal blades [fcap-002O]AGENTDRAFTED
Theorem. Strict-inversion multiplication of orthogonal blades [fcap-002O]AGENTDRAFTED
Let \(R\) be a commutative ring, \(M\) an \(R\)-module, \(Q\) a quadratic form on \(M\), and \(I\) a linearly ordered type. Suppose \(b_i\in M\) is a family satisfying \(B_Q(b_i,b_j)=0\) whenever \(i\ne j\). For a finite subset \(s\subset I\), let \(E_s\) be the product of the generators \(\iota _Q(b_i)\) in strictly increasing order, with \(E_\varnothing =1\). Put \[q_i=Q(b_i),\qquad N(s,t)=\#\{(i,j)\in s\times t:i>j\}.\] \[k(s,t)=(-1)^{N(s,t)}\prod _{i\in s\cap t}q_i.\] If \(\operatorname {sc}:R\to \mathcal {C}\kern -2pt\ell (Q)\) is the central scalar map, then \[E_sE_t=\operatorname {sc}(k(s,t))E_{s\mathbin {\triangle }t}.\] This identity needs no basis, field, nondegeneracy, inverse of \(2\), or invertibility of the \(q_i\). In particular, zero and zero-divisor metric factors remain in the formula.
Indeed, stably sort the concatenation of the increasing words for \(s\)
and \(t\). Each strict cross inversion \(i>j\) exchanges two distinct
orthogonal generators and contributes one minus sign. Equal indices are not
inversions. After sorting, the two copies of every \(i\in s\cap t\) are
adjacent and collapse by \(\iota _Q(b_i)^2=\operatorname {sc}(q_i)\). The
unpaired increasing indices are exactly \(s\mathbin {\triangle }t\). No step
divides or cancels a scalar
CliffordAlgebra.prod_map_ι_mul_ι_of_forall_isOrtho
CliffordAlgebra.prod_map_ι_sq_scalar.
Now additionally suppose that \(b\) is an \(R\)-basis and that \(2\) is invertible in \(R\). The increasing list attached to \(s\) is pairwise orthogonal, so Theorem [fcap-0006] identifies its Clifford product with the corresponding exterior monomial under \(T_Q\). Consequently \[E_s=B_{Q,b}(s),\] where \(B_{Q,b}\) is the particular transported exterior basis of Definition [fcap-0003]. This uses a supplied orthogonal basis; it does not assert that every quadratic form over every ring admits one.
Chevalley's ordered-monomial argument starts from \(x^2=Q(x)\) and \(xy+yx=B_Q(x,y)\) [chevalley1954algebraic, II.1.1--2, pp. 39--40]. [grinberg2016clifford, Theorem 2 and Definition 4, p. 3] gives the ascending finite-subset basis for finite free modules over a commutative ring, while [wieser2024formalizing, 2.1.2, (2.4) and Table 2.1, p. 7] checks adjacent swaps and repeated squares in Euclidean three-space. Wieser's dot product is \(B_Q/2\), and his cyclic slot \(e_ze_x\) is the negative of our increasing slot \(e_xe_z\). The strict inversion count and arbitrary diagonal factors above synthesize these calculations without importing that cyclic convention.
Proposition. Finite blade coordinates refine Clifford multiplication [fcap-002P]AGENTDRAFTED
Proposition. Finite blade coordinates refine Clifford multiplication [fcap-002P]AGENTDRAFTED
Retain the orthogonal \(R\)-basis \(b:I\to M\) and the inverse of \(2\) from the preceding theorem. Let \(\mathcal C\) be the \(R\)-module of finitely supported coefficient families \(c=(c_s)\) indexed by finite subsets of \(I\), and let \(\delta _s\) be its standard coordinate vectors. Define a bilinear product by the structure constants \[\delta _s\ast \delta _t =k(s,t)\delta _{s\mathbin {\triangle }t}.\] Equivalently, for every finite subset \(u\), \[(c\ast d)_u =\sum _{\substack {s\in \operatorname {supp}(c),\ t\in \operatorname {supp}(d)\\ s\mathbin {\triangle }t=u}} c_s d_t k(s,t).\] The sum and the resulting support are finite, even when \(I\) is infinite.
Let \[\eta (c)=\sum _s c_sE_s,\qquad \operatorname {enc}=\eta ^{-1}.\] The transported-basis identification in the preceding theorem makes \(\eta \) a linear equivalence, and its multiplication refinement is \[\eta (c\ast d)=\eta (c)\eta (d),\qquad \operatorname {enc}(xy) =\operatorname {enc}(x)\ast \operatorname {enc}(y).\] To prove the first equality, expand the two finite sums, apply the blade product to each pair, and regroup by symmetric difference. The second follows by applying \(\eta ^{-1}\). Thus the displayed structure constants, rather than an implicit transport definition, determine the coordinate product.
For example, work over \(\mathbb Q\) with ordered indices \(0<1<2\) and diagonal values \((q_0,q_1,q_2)=(0,2,-3)\). The formula gives \[\begin {aligned} E_{\{0,2\}}E_{\{1,2\}}&=3E_{\{0,1\}},& E_{\{1,2\}}E_{\{0,2\}}&=-3E_{\{0,1\}},\\ E_{\{0,1\}}E_{\{0,2\}}&=0,& E_{\{1,2\}}^2&=6. \end {aligned}\] The first product has one strict cross inversion, the second has two, and the third retains the repeated radical factor \(q_0=0\). Also \[(\delta _{\{0,2\}}+2\delta _{\{0,1\}})\ast \delta _{\{1,2\}} =3\delta _{\{0,1\}}+4\delta _{\{0,2\}}.\] This matches \((E_{\{0,2\}}+2E_{\{0,1\}})E_{\{1,2\}}\). Nonzero basis blades remain basis vectors although their products can vanish.
Orthogonality is essential to the symmetric-difference rule. Over \(\mathbb Q\), take \(Q(xe_0+ye_1)=x^2+xy+y^2\). Then \(B_Q(e_0,e_1)=1\) and \[T_Q(\iota _Q(e_0)\iota _Q(e_1)) =e_0\wedge e_1+\frac 12.\] The correction is the half-polar value. The general construction in Definition [fcap-0003] already gives \(T_Q\) as a linear equivalence; this example shows directly that it is not an algebra equivalence. The contraction and change-of-form recurrences in [wieser2024formalizing, 8.4, (8.54)--(8.55), p. 106] give the same sign and normalization.
The ascending-basis theorem and change-of-form maps in [grinberg2016clifford, Theorem 2, p. 3, and Theorems 34--35, pp. 55--56] corroborate the ordered basis and orthogonal transport. The latter is the specialization with symmetric half-polar form \(B_Q/2\); an arbitrary nonsymmetric form with the same diagonal need not define this transport. Wieser's exterior equivalence likewise assumes an inverse of \(2\) [wieser2024formalizing, 9.3.5, p. 120].
The displayed finite formula is a mathematical coordinate refinement. The currently public FCAP basis transport is noncomputable and does not expose an executable coordinate type, multiplication kernel, or encode/decode product theorem. Those declarations, together with any fixed finite-slot or floating-point contract, remain a separate implementation step.
Convention. Two coordinate orders for the degenerate projective plane [fcap-002Q]AGENTDRAFTED
Convention. Two coordinate orders for the degenerate projective plane [fcap-002Q]AGENTDRAFTED
Work over \(\mathbb R\) with an orthogonal frame \(e_0,e_1,e_2\) and \[Q(ae_0+be_1+ce_2)=b^2+c^2.\] Thus \(e_0^2=0\), \(e_1^2=e_2^2=1\), and distinct generators anticommute. Suppress the canonical generator map in products and write \(e_{ij}=e_ie_j\) and \(I=e_{012}\). This is the full degenerate Clifford algebra: no radical quotient is taken, \(I^2=0\), and \(I\) will never be inverted. The Euclidean row of Sokolov's metric table fixes this convention [sokolov2013foundations, Section 2.4, p. 20].
We will compare two mathematical basis orders. Sokolov's displayed order is \[S=(1,e_0,e_1,e_2,e_{12},e_{20},e_{01},e_{012}),\] whereas the ascending-mask order used by the preceding coordinate cards is \[C=(1,e_0,e_1,e_{01},e_2,e_{02},e_{12},e_{012}).\] The only change of blade orientation is \(e_{20}=-e_{02}\). These are declared mathematical orders; neither is an assertion about any software library's physical storage or iteration order. Sokolov's basis table appears with his duality calculation in [sokolov2013foundations, Section 2.6, p. 25].
Use nonzero homogeneous representatives \[L(d,a,b)=de_0+ae_1+be_2,\qquad P(w,x,y)=we_{12}+xe_{20}+ye_{01}\] for a projective line and point. A finite point has \(w\ne 0\) and may be normalized to \(w=1\); \(e_0\) is the ideal line, and every nonzero \(P(0,x,y)\) is an ideal point. These encodings and their ideal elements are the source conventions in [sokolov2013foundations, Section 2.9, pp. 32--33].
Proposition. The signed projective adapter preserves products and incidence [fcap-002R]AGENTDRAFTED
Proposition. The signed projective adapter preserves products and incidence [fcap-002R]AGENTDRAFTED
For the two orders in the preceding Convention, define \[\begin {aligned} \operatorname {toCore} &(s,c_0,c_1,c_2,c_{12},c_{20},c_{01},c_{012})\\ &=(s,c_0,c_1,c_{01},c_2,-c_{20},c_{12},c_{012}),\\ \operatorname {toNamed} &(r,r_0,r_1,r_{01},r_2,r_{02},r_{12},r_{012})\\ &=(r,r_0,r_1,r_2,r_{12},-r_{02},r_{01},r_{012}). \end {aligned}\] They are inverse linear maps on every eight-tuple. The minus sign is exactly \(e_{20}=-e_{02}\); substituting either displayed tuple into the other proves both round trips coordinate by coordinate.
This signed permutation also preserves the Clifford product, rather than merely being declared to do so. Encode the ascending blades by masks \(0,\ldots ,7\), with bit \(i\) representing \(e_i\), and put \[\sigma =(0,1,2,4,6,5,3,7),\qquad \epsilon =(1,1,1,1,1,-1,1,1).\] Then the \(i\)-th named blade is \(S_i=\epsilon _iC_{\sigma _i}\). For masks identified with subsets of \(\{0,1,2\}\), set \[g(m,n)=(-1)^{\#\{(i,j)\in m\times n:i>j\}} \prod _{i\in m\cap n}q_i, \qquad (q_0,q_1,q_2)=(0,1,1).\] The strict-inversion formula of Theorem [fcap-002O] gives \(C_mC_n=g(m,n)C_{m\mathbin {\triangle }n}\). If \(\sigma _k=\sigma _i\mathbin {\triangle }\sigma _j\), it follows that \[S_iS_j=\epsilon _i\epsilon _j\epsilon _k g(\sigma _i,\sigma _j)S_k.\] This checks every one of the \(64\) basis pairs, including the zero products caused by a repeated \(e_0\); bilinearity proves multiplication compatibility for arbitrary tuples. Addition, scalar multiplication, and the unit are preserved immediately.
The permutation \(\sigma \) preserves grade. Reversal multiplies a grade-\(k\) blade by \((-1)^{k(k-1)/2}\), so it commutes with the adapter. For exterior multiplication, the same crossing sign applies to disjoint masks and both sides vanish when masks overlap. Hence the adapter also preserves reversal and exterior multiplication. It therefore preserves inverses wherever they exist and, in particular, \[\operatorname {toCore}(MX\widetilde M) =\operatorname {toCore}(M)\operatorname {toCore}(X) \widetilde {\operatorname {toCore}(M)}.\] Under the ordered basis of Proposition [fcap-002P], these equations give the corresponding abstract-coordinate commuting square. They do not supply a named executable coordinate type or software-storage theorem.
For the projective representatives of the preceding Convention, direct exterior multiplication gives \[L(d,a,b)\wedge P(w,x,y)=(dw+ax+by)I.\] Since \(I\) is a nonzero basis blade, the point lies on the line precisely when \(dw+ax+by=0\); no inverse pseudoscalar is used. This agrees with Sokolov's incidence equation [sokolov2013foundations, (37), p. 25]. The four coordinate rows are \[\begin {aligned} [L(d,a,b)]_S&=(0,d,a,b,0,0,0,0),\\ [L(d,a,b)]_C&=(0,d,a,0,b,0,0,0),\\ [P(w,x,y)]_S&=(0,0,0,0,w,x,y,0),\\ [P(w,x,y)]_C&=(0,0,0,y,0,-x,w,0). \end {aligned}\] Thus the abstract incidence calculation and both coordinate presentations agree through the full adapter.
The ideal-direction sign is fixed by the same convention. Namely, \[e_0\wedge (ue_1+ve_2) =ue_{01}+ve_{02}=ue_{01}-ve_{20}=P(0,-v,u).\] The input pair \((u,v)\) is a line normal, while the resulting homogeneous point has direction \((-v,u)\). Direction \((u,v)\) itself is represented by \(P(0,u,v)\). This distinction keeps the algebraic encoding separate from a drawn arrow-orientation convention.
The result synthesizes Sokolov's projective encoding with the explicit blade kernel of Theorem [fcap-002O] and the finite coordinate refinement of Proposition [fcap-002P]. FCAP's current exterior-basis transport is noncomputable and does not yet expose these named conversion functions, an executable multiplication kernel, or compatibility theorems. Those implementation and external storage-order claims remain separate work.
Proposition. Translations and rotations form an exact plane-motor family [fcap-002S]AGENTDRAFTED
- September 27, 2026
Proposition. Translations and rotations form an exact plane-motor family [fcap-002S]AGENTDRAFTED
- September 27, 2026
Retain the real degenerate frame and projective encodings of
Convention [fcap-002Q]. Put \(E=e_{01}\). Since \(E^2=0\) and
\(\widetilde E=-E\), the one-axis motor
\[M_d=1-dE\]
satisfies
\[M_d^{-1}=\widetilde M_d=1+dE,\qquad
M_sM_t=M_{s+t}.\]
It belongs to the actual vector-generated Spin carrier because
\[M_d=e_1(e_1+de_0),\qquad
Q(e_1)=Q(e_1+de_0)=1\]
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
Direct sandwich multiplication gives
\[\begin {aligned}
M_dP(w,x,y)M_d^{-1}&=P(w,x+2dw,y),\\
M_dL(d_0,a,b)M_d^{-1}&=L(d_0-2da,a,b).
\end {aligned}\]
Thus the radical shear of Example [fcap-002N] is, in the fixed projective
encoding, translation by \((2d,0)\). The packaged nondegenerate transvection
theorem is not used.
For a general translation vector \(t=(t_x,t_y)\), define \[T(t)=1-\frac {t_x}{2}e_{01}+\frac {t_y}{2}e_{20}.\] Each increment squares to zero, and their products in either order vanish, so \[T(t)T(v)=T(t+v),\qquad T(t)^{-1}=T(-t).\] More precisely, \[T(t)= \left [e_1\left (e_1+\frac {t_x}{2}e_0\right )\right ] \left [e_2\left (e_2+\frac {t_y}{2}e_0\right )\right ].\] Every displayed vector has quadratic value \(1\); hence \(T(t)\) lies in the same actual Spin carrier. This is a direct factorization in the full degenerate Clifford algebra, not membership in a radical quotient.
Let \(c^2+s^2=1\) and put \[U=c-se_{12}=e_1(ce_1-se_2),\qquad U^{-1}=\widetilde U=c+se_{12}.\] Again both vector factors have quadratic value \(1\). Its active spatial matrix is \[R_U= \begin {pmatrix} c^2-s^2&-2cs\\ 2cs&c^2-s^2 \end {pmatrix}.\] For the ordered factorization \(M(t,U)=T(t)U\), which applies the rotation before the translation, write \(p=(x,y)\) and \(n=(a,b)\). Then \[\begin {aligned} (w,p)&\longmapsto (w,R_Up+wt),\\ (d,n)&\longmapsto (d-t\mathbin {\cdot }R_Un,R_Un). \end {aligned}\] The second row is the line action. It preserves incidence because \[(d-t\mathbin {\cdot }R_Un)w +(R_Un)\mathbin {\cdot }(R_Up+wt)=dw+n\mathbin {\cdot }p.\] In particular, translations fix every ideal point \((0,p)\). The selected family is closed, with exact order and inverse \[\begin {aligned} M(t,U)M(v,V)&=M(t+R_Uv,UV),\\ M(t,U)^{-1}&=M(-R_U^{-1}t,U^{-1}). \end {aligned}\] These formulas prove the claims for this family; they do not assert that every motor is a single exponential.
Sokolov's negative-half-angle rotor and nilpotent translator fix the sign and half-factor in this convention [sokolov2013foundations, (51)--(52), p. 39]. Independently, [dereli2010degenerate, Lemma 2.2, p. 567] proves \(\exp (aF)=1+aF\) for a radical vector \(F\); taking \(F=e_0\) and \(a=(t_xe_1+t_ye_2)/2\) gives exactly the increment of \(T(t)\). That paper later defines a quotient carrier [dereli2010degenerate, Definition 2.4, p. 570]; no such quotient is imported here. The vector-pair factorizations above establish membership in the carrier actually used in these notes.
Example. A rational motor checks every projective coordinate layer [fcap-002T]AGENTDRAFTED
- September 27, 2026
Example. A rational motor checks every projective coordinate layer [fcap-002T]AGENTDRAFTED
- September 27, 2026
Take \[c=\frac 35,\qquad s=\frac 45,\qquad t=(4,0).\] Then \[U=\frac {3-4e_{12}}5,\qquad R_U=\frac 1{25}\begin {pmatrix}-7&-24\\24&-7\end {pmatrix},\] and the ordered motor is \[M=T(4,0)U =\frac 35-\frac 45e_{12}-\frac 85e_{20}-\frac 65e_{01}.\] Its full named tuple and the ascending core tuple supplied by Proposition [fcap-002R] are \[\begin {aligned} \operatorname {named}(M) &=\left (\frac 35,0,0,0,-\frac 45,-\frac 85,-\frac 65,0\right ),\\ \operatorname {core}(M) &=\left (\frac 35,0,0,-\frac 65,0,\frac 85,-\frac 45,0\right ). \end {aligned}\] Thus the calculation enters the algebra through all eight-coordinate conversion data, including the \(e_{20}=-e_{02}\) sign.
The point and line \[P_0=P(1,3,-1),\qquad L_0=L(3,-1,0)\] are incident. The motor action gives \[\begin {aligned} MP_0M^{-1}&=P\left (1,\frac {103}{25},\frac {79}{25}\right ),\\ ML_0M^{-1}&=L\left (\frac {47}{25},\frac 7{25},-\frac {24}{25}\right ). \end {aligned}\] The output incidence check is \[\frac {47}{25} +\frac 7{25}\frac {103}{25} -\frac {24}{25}\frac {79}{25}=0.\] The output point has tuples \[\begin {aligned} \operatorname {named}(MP_0M^{-1}) &=\left (0,0,0,0,1,\frac {103}{25},\frac {79}{25},0\right ),\\ \operatorname {core}(MP_0M^{-1}) &=\left (0,0,0,\frac {79}{25},0,-\frac {103}{25},1,0\right ). \end {aligned}\] This checks the geometric action and the signed coordinate adapter on the same exact example.
Reversal gives the algebra inverse, and sandwiching the two outputs by \(\widetilde M\) and \(M\) returns both original representatives. In the same ordered factorization, \[M^{-1}=M\left (\left (\frac {28}{25},\frac {96}{25}\right ),U^{-1}\right ).\] Composition order is visible: reversing the factors gives \[UT(4,0):P(1,3,-1)\longmapsto P(1,-1,7),\] which differs from the output above. These are exact rational identities, not floating-point or private-software evidence. FCAP does not yet expose the named executable product and conversion theorems needed to certify this calculation as a public implementation refinement.
Spin-representation roadmap [fcap-0019]AGENTDRAFTED
Spin-representation roadmap [fcap-0019]AGENTDRAFTED
This appendix follows the mathematical dependencies organized by the spin-representation roadmap and the orthogonal Spin-groups roadmap of Tau Ceti. The first organizes the filtered Clifford algebra, bivectors, spinor modules, and real classification. The second organizes reflections, the Pin and Spin covers, Clifford norms, and the orthogonal action. These roadmaps guide the scope and dependencies below; formalization links refer to specific landed declarations.
The filtered Clifford algebra first exposes its exterior shadow. Reflections then lead to the global Pin and Spin extensions, while bivectors provide the algebraic infinitesimal orthogonal action. A polar-dual basis turns that action into a coordinate lift, and the Killing pairing gives the adjoint case. The Lie functor records the separate differential bridge from smooth group homomorphisms. A polarization joins the algebraic group and Lie constructions in the exterior spinor model. The real-signature recurrence and classification form a parallel algebraic branch and do not depend on the spinor-module or double-cover join.
The exterior shadow of a Clifford algebra [fcap-000F]AGENTDRAFTED
The exterior shadow of a Clifford algebra [fcap-000F]AGENTDRAFTED
The Clifford relation lowers word length by two. Filtering by word length therefore separates a word from its contraction terms: the highest-degree part is alternating, and the associated graded algebra is the exterior algebra. Reversal then distinguishes word order from parity, while orthogonality gives a scalar square for a volume word.
§ [ca-0001]
Definition. Word-length filtration [chevalley1954algebraic, II.1.2 and II.1.6, pp. 40--42] [fcap-000G]
L∃∀NAGENTDRAFTED
Definition. Word-length filtration [chevalley1954algebraic, II.1.2 and II.1.6, pp. 40--42] [fcap-000G]
L∃∀NAGENTDRAFTED
Chevalley constructs the classical filtration after choosing a finite basis of a vector space over a field. TauCeti's coordinate-free version below is defined for a quadratic form on a module over a commutative ring. The leading-symbol equivalences in Lemma [fcap-000H] and Theorem [fcap-000I] additionally assume that \(2\) is invertible.
Let \(R\) be a commutative ring, let \(M\) be an \(R\)-module, and let \(Q:M\to R\) be a quadratic form. In the Clifford algebra \(\mathcal {C}\kern -2pt\ell (Q)\), define \(F_n\mathcal {C}\kern -2pt\ell (Q)\) to be the \(R\)-submodule spanned by all products of at most \(n\) generators: \[F_n\mathcal {C}\kern -2pt\ell (Q)=\operatorname {span}_R\left \{\iota (v_1)\cdots \iota (v_r):0\le r\le n\right \}.\] The empty product gives \(F_0\mathcal {C}\kern -2pt\ell (Q)=R1\). Concatenating words makes the filtration multiplicative; in fact, \[F_i\mathcal {C}\kern -2pt\ell (Q)\,F_j\mathcal {C}\kern -2pt\ell (Q)=F_{i+j}\mathcal {C}\kern -2pt\ell (Q).\] Thus multiplication descends to the successive quotients and makes \[\operatorname {gr}_F\mathcal {C}\kern -2pt\ell (Q)=\bigoplus _{n\ge 0}F_n\mathcal {C}\kern -2pt\ell (Q)/F_{n-1}\mathcal {C}\kern -2pt\ell (Q)\] a graded algebra, with \(F_{-1}\mathcal {C}\kern -2pt\ell (Q)=0\).
Lemma. The leading symbol is exterior [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000H]
Lemma. The leading symbol is exterior [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000H]
Retain the coordinate-free commutative-ring and module setting of Definition [fcap-000G], and assume that \(2\) is invertible in \(R\). This is TauCeti's extension of Chevalley's finite-basis, vector-space leading-symbol argument. For vectors \(v_1,\ldots ,v_n\in M\), the Clifford relation replaces an interchange by its alternating term plus a scalar contraction. Each contraction removes two generators. Consequently \[\iota (v_1)\cdots \iota (v_n) \equiv v_1\wedge \cdots \wedge v_n\pmod {F_{n-2}},\] where the right-hand side is read through the zero-form exterior model. In particular, the class of the Clifford word in \(F_n/F_{n-1}\) depends alternately on the vectors and is the leading exterior symbol.
Proof.
Proof.
Move a generator through the word using \[\iota (u)\iota (v)+\iota (v)\iota (u)=B_Q(u,v)1.\] The swapped word contributes the alternating sign, whereas the polar term has two fewer generators. Iterating separates the fully alternating word from terms in \(F_{n-2}\). Equivalently, changing from \(Q\) to the zero quadratic form changes a word only below its leading filtration degree.
Theorem. The graded pieces are exterior powers [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000I]
Theorem. The graded pieces are exterior powers [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000I]
Let \(R\), \(M\), and \(Q\) be as in Lemma [fcap-000H]. Chevalley's finite-dimensional field argument motivates the identification. TauCeti proves the following coordinate-free commutative-ring and module equivalence. For every \(n\ge 0\), the leading-symbol map gives \[F_n\mathcal {C}\kern -2pt\ell (Q)/F_{n-1}\mathcal {C}\kern -2pt\ell (Q)\simeq \bigwedge ^n_R M.\] At \(n=0\) this is the scalar equivalence \(F_0/0\simeq R=\bigwedge ^0_RM\). For \(n>0\), the inverse sends a decomposable exterior product to the class of the corresponding Clifford word.
The point of the quotient is that every contraction term has already fallen into a lower filtration step. Alternation is therefore exact in the graded piece even though it is not exact in the Clifford algebra itself.
Theorem. PBW equivalence with the exterior algebra [meinrenken2013clifford, Proposition 2.6, pp. 33--34] [fcap-000J]
L∃∀NAGENTDRAFTED
Theorem. PBW equivalence with the exterior algebra [meinrenken2013clifford, Proposition 2.6, pp. 33--34] [fcap-000J]
L∃∀NAGENTDRAFTED
Meinrenken's Proposition 2.6 assumes a finite-dimensional vector space over a characteristic-zero field. TauCeti proves the corresponding extension for an additive commutative group \(M\) with a module structure over a commutative ring \(R\), a quadratic form \(Q\) on \(M\), and invertible \(2\in R\). Under these hypotheses, the equivalences of Theorem [fcap-000I] respect multiplication of homogeneous classes and assemble into a graded-algebra equivalence \[\operatorname {gr}_F\mathcal {C}\kern -2pt\ell (Q)\simeq _{\mathrm {grAlg}}\bigwedge _R M.\] The class of a product of an \(i\)-word and a \(j\)-word is carried to the exterior product of their leading symbols in degree \(i+j\).
This is a PBW theorem for the Clifford filtration. It does not make \(\mathcal {C}\kern -2pt\ell (Q)\) and \(\bigwedge _RM\) isomorphic as algebras. The quadratic form survives in the lower-degree contraction terms of Clifford multiplication; only the associated graded multiplication forgets it.
Example. The degree-two symbol [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000K]
L∃∀NAGENTDRAFTED
Example. The degree-two symbol [chevalley1954algebraic, II.1.6, pp. 41--42] [fcap-000K]
L∃∀NAGENTDRAFTED
Let \(R\), \(M\), and \(Q\) be as in Definition [fcap-000G], and assume \(2\) is invertible in \(R\), as in Lemma [fcap-000H]. For \(u,v\in M\), the degree-two leading-term map sends their exterior product to the class of the corresponding Clifford word. Writing that word as \[\iota (u)\iota (v) =\frac 12\bigl (\iota (u)\iota (v)-\iota (v)\iota (u)\bigr ) +\frac 12B_Q(u,v)1.\] The second summand belongs to \(F_0\), so it vanishes in \(F_2/F_1\). Thus \(u\wedge v\) maps to the class of \(\iota (u)\iota (v)\); equivalently, under the graded-piece equivalence, that class maps to \(u\wedge v\). This is the two-generator instance of Chevalley's leading-symbol calculation cited in the title. The surviving half-commutator is the Clifford bivector studied next; the scalar polar term is invisible to the leading symbol.
Remark. Basis proof and quotient proof [fcap-000L]AGENTDRAFTED
Remark. Basis proof and quotient proof [fcap-000L]AGENTDRAFTED
Chevalley's proof chooses a basis, proves that ordered Clifford monomials form a basis, and identifies the underlying vector space with the exterior algebra [chevalley1954algebraic, II.1.2 and II.1.6, pp. 40--42]. Panyushev uses the resulting stable filtration and exterior associated graded as standard representation-theoretic background [panyushev2001exterior, Section 2, p. 7].
The quotient construction above is TauCeti's coordinate-free commutative-ring and module extension of that finite-dimensional field proof. It builds each graded piece from the word-length submodule and its predecessor, handles degree zero separately, and then takes their direct sum. This is a change of packaging and generality, not a stronger claim about unfiltered Clifford multiplication.
Theorem. Scalar extension preserves the Clifford and exterior constructions [fcap-003V]
Theorem. Scalar extension preserves the Clifford and exterior constructions [fcap-003V]
Changing the field need not require new generators or a new quadratic basis. Let \(L/K\) be a field extension with \(\operatorname {char}K\ne 2\), and let \((V,Q)\) be a finite-dimensional quadratic space, possibly degenerate. Its scalar extension is \(V_L=L\otimes _K V\) with quadratic form \(Q_L\) characterized by \(Q_L(a\otimes v)=a^2Q(v)\) and the extended polar form. There are canonical \(L\)-algebra isomorphisms \[\begin {aligned} \beta _Q:L\otimes _K\mathcal {C}\kern -2pt\ell _K(Q)&\longrightarrow \mathcal {C}\kern -2pt\ell _L(Q_L),\\ a\otimes \iota _Q(v)&\longmapsto a\,\iota _{Q_L}(1\otimes v),\\ \beta _\wedge :L\otimes _K\bigwedge _K V&\longrightarrow \bigwedge _L V_L,\\ a\otimes (v_1\wedge \cdots \wedge v_r)&\longmapsto a(1\otimes v_1)\wedge \cdots \wedge (1\otimes v_r). \end {aligned}\] The first preserves the word-length filtration and parity; the second preserves exterior degree. No nondegeneracy hypothesis or chosen basis is needed to define either map.
The Clifford statement is [chevalley1954algebraic, II.1.5, p. 41]. The proof below uses the universal property; applying it to the zero form gives the exterior algebra statement.
Proof.
Proof.
The assignment \(v\mapsto \iota _{Q_L}(1\otimes v)\) has square \(Q(v)1\). The universal property extends it to a \(K\)-algebra map; extending scalars gives \(\beta _Q\). For the inverse, take the \(L\)-linear map \[j:V_L\longrightarrow L\otimes _K\mathcal {C}\kern -2pt\ell _K(Q),\qquad j(a\otimes v)=a\otimes \iota _Q(v).\] The Clifford anticommutator is \(\iota _Q(v)\iota _Q(w)+ \iota _Q(w)\iota _Q(v)=B_Q(v,w)1\). Thus, for \(x=\sum _i a_i\otimes v_i\), \[j(x)^2=\left (\sum _i a_i^2Q(v_i)+ \sum _{i<j}a_ia_jB_Q(v_i,v_j)\right )1=Q_L(x)1.\] The same universal property therefore extends \(j\) to an \(L\)-algebra map in the opposite direction. Both composites fix scalars and vector generators, so they are identities. For \(Q=0\), this argument gives \(\beta _\wedge \). The two maps and their inverses preserve word length and parity because they send generators to generators.
Write \(C=\mathcal {C}\kern -2pt\ell _K(Q)\) and \(C_L=\mathcal {C}\kern -2pt\ell _L(Q_L)\), and denote the leading-symbol equivalences of Theorem [fcap-000I] by \(\sigma _K,\sigma _L\). Scalar extension and taking the exterior symbol commute:
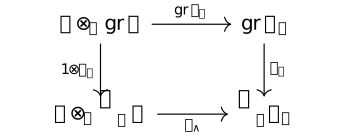
For example, \(\beta _Q(1\otimes \iota _Q(v)^2)=Q(v)1\), whereas \((1\otimes v)\wedge (1\otimes v)=0\). The square compares associated graded multiplication. It does not turn the linear Clifford-to-exterior coordinates of Definition [fcap-0003] into an algebra map. Chevalley makes this product distinction immediately after II.1.5.
The marked declarations give the two algebra equivalences in the reverse direction. Mathlib allows arbitrary commutative base and extension rings with \(2\) invertible; TauCeti's exterior equivalence needs neither invertible two nor flatness. The symbol square above is the consequence proved here, using the existing leading-symbol equivalence. The separate Spin-lifting consequences remain in Theorem [fcap-003N] and Proposition [fcap-003O].
Theorem [ca-000C]Definition [ca-000E]
Example. Real structures in chosen complex coordinates [fcap-003W]AGENTDRAFTED
Example. Real structures in chosen complex coordinates [fcap-003W]AGENTDRAFTED
Why does the complex Clifford algebra forget a real signature, while its real vectors still remember it? Let \(V\) be a finite-dimensional real space with nondegenerate quadratic form \(Q\). Its complexification is the scalar extension \(V_{\mathbb C}=\mathbb C\otimes _{\mathbb R}V\). Complex conjugation on the first factor fixes \(V\) and induces the conjugate-linear algebra involution \[\sigma (z\otimes a)=\overline z\otimes a\] on \(\mathbb C\otimes _{\mathbb R}\mathcal {C}\kern -2pt\ell _{\mathbb R}(Q)\). It preserves product order and conjugates scalar coefficients; the grade reversion instead reverses product order and is complex-linear after scalar extension. A real structure on a complex vector space or algebra means a map with \(\sigma (\lambda v+\mu w)=\overline \lambda \sigma (v)+ \overline \mu \sigma (w)\) and \(\sigma ^2=1\), an algebra automorphism in the algebra case. The fixed algebra here is \(1\otimes \mathcal {C}\kern -2pt\ell _{\mathbb R}(Q)\): write an element uniquely as \(1\otimes a+i\otimes b\) with \(a,b\) real to check this.
For the underlying real module of \(\mathcal {C}\kern -2pt\ell _{\mathbb R}(Q)\), this
coefficient map is TauCeti.tmulConj.
Its involution law is TauCeti.tmulConj_involutive, and
its fixed vectors are described by
TauCeti.tmulConj_eq_self_iff.
These supporting declarations concern the conjugate-linear involution and
fixed vectors; multiplicativity and the coordinate comparisons below are
the algebra calculations given here.
This is the conjugation construction in [meinrenken2013clifford, Section 2.2.6, p. 34]. Meinrenken's symmetric form is \(B=B_Q/2\), so his generator relation is \(uv+vu=2B(u,v)=B_Q(u,v)\). The following coordinate calculation applies that construction to the scalar-extension isomorphism of Theorem [fcap-003V].
Choose an orthogonal real basis \(e_1,\ldots ,e_n\) with \(Q(e_j)=1\) for \(j\le p\) and \(Q(e_j)=-1\) for \(j>p\), where \(n=p+q\). These are the signature signs of Convention [fcap-0011]. On \(\mathbb C^n\), put \(Q_0(z)=\sum _j z_j^2\), with coordinate vectors \(u_j\). The chosen complex isometry \[T(e_j)=\begin {cases}u_j&j\le p,\\i u_j&j>p\end {cases}\] induces \(\mathcal {C}\kern -2pt\ell (T):\mathcal {C}\kern -2pt\ell _{\mathbb C}(Q_{\mathbb C}) \simeq \mathcal {C}\kern -2pt\ell _{\mathbb C}(Q_0)\). Transporting \(\sigma \) through this map and Theorem [fcap-003V] gives \(\sigma _T\) on the standard complex algebra. On its generators, \[\sigma _T(\iota (u_j))=\begin {cases} \iota (u_j)&j\le p,\\-\iota (u_j)&j>p. \end {cases}\] Indeed, \(T^{-1}(u_j)=-i e_j\) for a negative direction, and conjugation sends this to \(i e_j\), whose image under \(T\) is \(-u_j\). The fixed real generators are consequently \(\iota (u_j)\) and \(i\iota (u_j)\) in the positive and negative directions, respectively.
Already in dimension one, the same complex algebra \(A=\mathbb C[u]/(u^2-1)\) has two different real structures: \[\begin {aligned} \sigma _+(z+wu)&=\overline z+\overline w u, & A^{\sigma _+}&=\mathbb R[ u]\simeq \mathbb R\oplus \mathbb R,\\ \sigma _-(z+wu)&=\overline z-\overline w u, & A^{\sigma _-}&=\mathbb R[iu]\simeq \mathbb C. \end {aligned}\] The first real-algebra isomorphism evaluates at \(u=1,-1\); the second uses \((iu)^2=-1\). Thus forgetting the real structure loses the distinction between \(\mathcal {C}\kern -2pt\ell (1,0)\) and \(\mathcal {C}\kern -2pt\ell (0,1)\). If a different complex isometry is \(T'=UT\), then \(\sigma _{T'}=\mathcal {C}\kern -2pt\ell (U)\sigma _T\mathcal {C}\kern -2pt\ell (U)^{-1}\). The real structure moves with the coordinates; it is not generally entrywise conjugation in every model.
The real-algebra identifications in this example are formalized as
TauCeti.realCliffordOneZeroEquivProd and
TauCeti.realCliffordZeroOneEquivComplex.
These declarations identify the two real Clifford algebras; the comparison
of their conjugations inside \(A\) is the calculation above.
Choosing the polarization data for a spinor carrier is a further choice. For \(Q(x,y)=x^2+y^2\), the complex isotropic lines \[W=\mathbb C(e_1+i e_2),\qquad W'=\mathbb C(e_1-i e_2)\] are complementary, and conjugation exchanges them. Their polar pairing is nonzero, so they give the split model after normalizing a dual basis. The carrier \(S=\bigwedge W\) uses \(W\) for creation and \(W'\) for contraction, as in Definition [fcap-001I]. Conjugation therefore maps this exterior space to \(\bigwedge W'\), rather than supplying a conjugation on \(S\) compatible with the same chosen operators. Comparing these carriers needs an additional intertwining map. This explains why the canonical real structure on the Clifford algebra alone does not choose a real structure on a particular spinor module. The creation/contraction construction is [chevalley1954algebraic, II.2.1--II.2.2, pp. 42--44].
Definition [ca-000J]
Lemma. Parity and reversal separate on bivectors [fcap-0021]
L∃∀NAGENTDRAFTED
Lemma. Parity and reversal separate on bivectors [fcap-0021]
L∃∀NAGENTDRAFTED
Let \(R\) be a commutative ring with invertible \(2\), let \(M\) be an \(R\)-module, and let \(Q\) be a quadratic form on \(M\). Write \(\alpha \) for the grading involution and \(\operatorname {rev}\) for reversal. For the half-commutator bivector of Convention [fcap-000N], \[\begin {aligned} \alpha (\beta _Q(u,v))&=\beta _Q(u,v),\\ \operatorname {rev}(\beta _Q(u,v))&=-\beta _Q(u,v). \end {aligned}\] The same reversal sign holds for every bivector in the image of \(\bigwedge _R^2 M\); reversal acts as minus the identity there.
Chevalley defines the main antiautomorphism by reversing products while fixing generators [chevalley1954algebraic, Section 2.1, p. 38]. His parity decomposition identifies even exterior degree with the even Clifford part [chevalley1954algebraic, II.1.6, p. 42]. Those are finite-dimensional field-space conventions; the displayed bivector statement is Tau Ceti's commutative-ring extension.
Proof.
Proof.
Parity changes the sign of each generator, so it fixes a product of
two. Reversal exchanges the order of those generators. Applied to the
half-commutator, the exchange negates it. Linearity then gives the same
sign on the exterior-square image
CliffordAlgebra.reverse_bivectorExterior.
The bivector is even
CliffordAlgebra.bivector_mem_evenOdd_zero;
on any even element reversal also agrees with Clifford conjugation
\(x\mapsto x^*\), since parity is the identity there
CliffordAlgebra.reverse_eq_star_of_mem_even.
The same reversal and parity conventions determine the scalar norm signs and the distinction between even-unitary and Spin units in Remark [fcap-0028].
Remark. Reverse norm signs and the Spin carrier [fcap-0028]AGENTDRAFTED
Remark. Reverse norm signs and the Spin carrier [fcap-0028]AGENTDRAFTED
Let \(R\) be a commutative ring, let \(M\) be an \(R\)-module, and let
\(Q\) be a quadratic form on \(M\). Write \(\widehat v=\iota _Q(v)\) for a
Clifford generator. Before imposing any invertibility condition, consider the
two algebra-valued norm expressions
\(N_{\mathrm {rev}}(x)=\operatorname {rev}(x)x\) and \(N_*(x)=x^*x\), where
\(x^*=\operatorname {rev}(\alpha (x))\). Identifying a scalar with its image in
the Clifford algebra gives
\[\begin {aligned}
N_{\mathrm {rev}}(\widehat v)&=Q(v),
&N_*(\widehat v)&=-Q(v),\\
N_{\mathrm {rev}}(\widehat u\widehat v)
&=\widehat v\widehat u\widehat u\widehat v
=Q(u)Q(v),
&N_*(\widehat u\widehat v)&=Q(u)Q(v).
\end {aligned}\]
Thus the two signs differ on one generator and agree on a product of two.
More generally, reversal gives the product of the quadratic values on every
vector word
CliffordAlgebra.reverse_prod_map_ι_mul_prod_map_ι, and the
two norm expressions agree on every even Clifford element
CliffordAlgebra.star_mul_self_eq_reverse_mul_self_of_mem_even.
For a Clifford unit \(x\), membership in the even-unitary carrier is
equivalent to evenness together with \(N_{\mathrm {rev}}(x)=1\)
CliffordAlgebra.evenUnitaryGroup.mem_iff_reverse_mul_self_eq_one.
Those two conditions do not establish Lipschitz membership, which must be
retained in the Spin criterion. Precisely,
\[\operatorname {im}\bigl (\operatorname {Spin}(Q)\longrightarrow
\operatorname {Cl}(Q)^\times \bigr )
=\operatorname {Lipschitz}(Q)\cap \operatorname {EvenUnitary}(Q)\]
CliffordAlgebra.range_spinGroup_toUnits.
Consequently, if \(Q(u)Q(v)=1\), then \(\widehat u\widehat v\) is an even
product of Lipschitz vector units with reverse norm one, hence a Spin element
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
This is an unquotiented scalar calculation. The passage to square classes,
including the odd reflection sign and its cancellation on even products, is
recorded separately in Theorem [fcap-0023].
Chevalley obtains the same norm from what he calls the main antiautomorphism and records \(\lambda (v)=Q(v)\) and the paired values \(Q(u)Q(v)\) [chevalley1954algebraic, II.3.5--6, pp. 52--53]. His symbol \(\alpha \) in that passage denotes reversal, whereas \(\alpha \) in Lemma [fcap-0021] denotes the grading involution. Meinrenken calls reversal transposition, writes \(N(x)=x^\top x\), and defines Spin as its norm-one subgroup inside the special Clifford group [meinrenken2013clifford, Sections 2.2.6 and 3.1.1--2, pp. 34, 49--51]. His convention has \(Q(v)=B(v,v)\), so his \(B\) is the half-polar form \(b_Q\) of Convention [fcap-0027]. Both sources work in narrower finite-dimensional field settings; Meinrenken here assumes characteristic zero and a nondegenerate form. The formal identities linked above hold under the commutative-ring and module hypotheses stated here.
Theorem. The square of an orthogonal Clifford volume word [fcap-0022]
L∃∀NAGENTDRAFTED
Theorem. The square of an orthogonal Clifford volume word [fcap-0022]
L∃∀NAGENTDRAFTED
Let \(R\) be a commutative ring, \(M\) an \(R\)-module, and \(Q\) a quadratic form on \(M\). For a pairwise \(Q\)-orthogonal list \(\ell =(v_1,\ldots ,v_n)\), set \[\omega _\ell =\iota _Q(v_1)\cdots \iota _Q(v_n).\] Its square is the scalar \[\omega _\ell ^2 =(-1)^{\binom n2}\left (\prod _{i=1}^{n}Q(v_i)\right )1.\] The empty list gives \(\omega _\ell =1\). No basis, nondegeneracy, finite-dimensionality, or invertibility of \(2\) is required.
Chevalley computes the corresponding square for an orthogonal basis of a nondegenerate even-dimensional quadratic space over a field of characteristic different from \(2\) [chevalley1954algebraic, Proof of II.2.3, p. 45]. His generator relation \(v_i^2=Q(v_i)1\) matches the convention above. Tau Ceti's list identity extends that calculation to arbitrary lengths and the stated commutative-ring setting.
Proof.
Proof.
Pairwise orthogonality gives \(\iota _Q(v_i)\iota _Q(v_j)=-\iota _Q(v_j)\iota _Q(v_i)\) for \(i\ne j\). Move each factor of the second copy of \(\omega _\ell \) next to its matching factor in the first copy. This takes \((n-1)+(n-2)+\cdots +1=\binom n2\) swaps. Each adjacent pair then contracts to \(\iota _Q(v_i)^2=Q(v_i)1\), giving the formula.
Reflections and square-normalized Clifford lifts [fcap-0007]AGENTDRAFTED
Reflections and square-normalized Clifford lifts [fcap-0007]AGENTDRAFTED
A nonisotropic vector acts on the generating space by a reflection through twisted Clifford conjugation. Normalizing such vectors gives elements of Pin, while determinant parity detects the even products that belong to Spin. The cards pass from local lifts to reflection generation, Pin surjectivity, and finally Spin surjectivity onto the special orthogonal group.
§ [ca-0001]
Convention. Quadratic-form sign [lawson2016spin, I.1, (1.3)--(1.4), p. 8] [fcap-0008]AGENTDRAFTED
Convention. Quadratic-form sign [lawson2016spin, I.1, (1.3)--(1.4), p. 8] [fcap-0008]AGENTDRAFTED
Lawson and Michelsohn write
\[v^2=-q(v)1, \qquad vw+wv=-2q(v,w),\]
where \(2q(v,w)=q(v+w)-q(v)-q(w)\). Mathlib and TauCeti instead use a quadratic form \(Q\) with
\[\iota (v)^2=Q(v)1.\]
The conventions agree after setting \(Q=-q\). The orthogonal group and its reflections are unchanged by this global sign reversal. A vector with \(q(v)=1\) therefore has \(Q(v)=-1\) in the convention used below. Mathlib's generator-square rule CliffordAlgebra.ι_sq_scalar uses this \(Q\)-convention.
Definition. Reflection in a nonisotropic vector [lawson2016spin, I.2, (2.12), p. 14] [fcap-0009]
L∃∀NAGENTDRAFTED
Definition. Reflection in a nonisotropic vector [lawson2016spin, I.2, (2.12), p. 14] [fcap-0009]
L∃∀NAGENTDRAFTED
Let \(F\) be a field of characteristic different from \(2\), let \(Q\) be a quadratic form on an \(F\)-vector space \(V\), and write \[B_Q(x,y)=Q(x+y)-Q(x)-Q(y)\] for its polar form. If \(Q(v)\ne 0\), the reflection with normal vector \(v\) is \[\rho _v(w)=w-\frac {B_Q(v,w)}{Q(v)}v.\] It fixes \(v^\perp \) pointwise, sends \(v\) to \(-v\), and preserves \(Q\). Multiplying \(v\) by a nonzero scalar does not change \(\rho _v\).
Lemma. Twisted Clifford conjugation is a reflection [lawson2016spin, I.2, Proposition 2.2 and (2.8), p. 13; (2.11)--(2.12), p. 14] [fcap-000A]AGENTDRAFTED
Lemma. Twisted Clifford conjugation is a reflection [lawson2016spin, I.2, Proposition 2.2 and (2.8), p. 13; (2.11)--(2.12), p. 14] [fcap-000A]AGENTDRAFTED
Let \(\alpha \) denote the grading involution of \(\mathcal {C}\kern -2pt\ell (Q)\). For \(Q(v)\ne 0\), the Clifford generator \(\iota (v)\) is invertible with \[\iota (v)^{-1}=Q(v)^{-1}\iota (v).\] Its twisted adjoint action on a generator is the reflection in Definition [fcap-0009]: \[\alpha (\iota (v))\,\iota (w)\,\iota (v)^{-1}=\iota (\rho _v(w)).\]
Proof.
Proof.
The generator-square rule CliffordAlgebra.ι_sq_scalar and the anticommutator rule CliffordAlgebra.ι_mul_ι_add_swap give
\[\iota (v)\iota (w)+\iota (w)\iota (v)=B_Q(v,w).\]
Since \(\alpha (\iota (v))=-\iota (v)\) and \(\iota (v)^2=Q(v)\), substitution yields
\[-\iota (v)\iota (w)\frac {\iota (v)}{Q(v)}
=\iota (w)-\frac {B_Q(v,w)}{Q(v)}\iota (v)
=\iota (\rho _v(w)).\]
The ordinary adjoint differs by the leading minus sign; the twisted adjoint is the action that gives the reflection itself.
Lemma. Square-normalized Pin lift [lawson2016spin, I.2, Definition 2.3 and (2.26), pp. 14, 18] [fcap-000B]
L∃∀NAGENTDRAFTED
Lemma. Square-normalized Pin lift [lawson2016spin, I.2, Definition 2.3 and (2.26), pp. 14, 18] [fcap-000B]
L∃∀NAGENTDRAFTED
Lawson--Michelsohn make this product-and-scaling argument for a finite-dimensional quadratic vector space over a field. The statement below is TauCeti's extension to a quadratic module over a commutative ring. It assumes that \(2\) and \(Q(v)\) are invertible.
Let \(R\) be a commutative ring, let \(Q\) be a quadratic form on an \(R\)-module \(M\), and suppose \(2\) and \(Q(v)\) are invertible. If there is a scalar \(c\) such that \[c^2=-Q(v)^{-1},\] then \(Q(cv)=-1\). The normalized Clifford generator \(\iota (cv)\) belongs to the Pin group and its twisted adjoint action is \(\rho _v\), because \(\rho _{cv}=\rho _v\). Consequently \[\rho _v\in \operatorname {range}(\operatorname {pinToOrthogonal}).\] Equivalently, the required hypothesis is that \(-Q(v)^{-1}\) is a square. The conclusion is existential: it asserts that a Pin lift exists, not that a canonical square root has been chosen.
Theorem. Paired reflections have a product-square Spin lift [lawson2016spin, I.2, (2.24)--(2.26), p. 18] [fcap-000C]
L∃∀NAGENTDRAFTED
Theorem. Paired reflections have a product-square Spin lift [lawson2016spin, I.2, (2.24)--(2.26), p. 18] [fcap-000C]
L∃∀NAGENTDRAFTED
The cited product formulas are stated for a finite-dimensional quadratic vector space over a field. TauCeti packages the same scaling and Clifford-product calculation over the commutative-ring and module hypotheses inherited from Lemma [fcap-000B].
Let \(R\), \(M\), and \(Q\) be as in Lemma [fcap-000B]. Suppose \(Q(v)\), \(Q(w)\), and \(2\) are invertible. If there is a scalar \(c\) such that \[c^2=Q(v)^{-1}Q(w)^{-1},\] then \[Q(cv)Q(w)=1.\] Set \(x=\iota (cv)\iota (w)\). The element \(x\) is a product of invertible Clifford generators, and \[x^{*}x =\iota (w)\iota (cv)^2\iota (w) =Q(cv)Q(w)=1.\] Thus \(x\) is a unitary element of the Lipschitz group. It has even degree, so it belongs to the Spin group. Its twisted adjoint action is the ordered product of reflections, and therefore \[\rho _v\rho _w\in \operatorname {range}(\operatorname {spinToOrthogonal}).\]
Proof.
Proof.
The displayed square identity gives \(Q(cv)Q(w)=c^2Q(v)Q(w)=1\). Each generator is a Clifford unit and lies in the Lipschitz group, while the star calculation above establishes the unitary condition. The twisted adjoint is multiplicative on Clifford units, and scalar rescaling does not change a reflection. Hence the action of \(x\) is \(\rho _{cv}\rho _w=\rho _v\rho _w\); its even degree supplies the remaining Spin condition.
Equations (2.24)--(2.26) give the product descriptions and scaling invariance used here. The product-square condition is sharper than asking for separate normalizations of \(v\) and \(w\): one scalar normalizes the product even when neither vector has been normalized separately.
Example. A Euclidean unit normal [lawson2016spin, I.2, (2.12), p. 14; (2.24)--(2.26), p. 18] [fcap-000D]AGENTDRAFTED
Example. A Euclidean unit normal [lawson2016spin, I.2, (2.12), p. 14; (2.24)--(2.26), p. 18] [fcap-000D]AGENTDRAFTED
Let \(V=\mathbb {R}^n\) with Euclidean inner product and use the sign convention \[Q(x)=-\langle x,x\rangle .\] For a unit vector \(v\), one has \(Q(v)=-1\); thus \(c=1\) satisfies the square condition in Lemma [fcap-000B]. The Clifford generator \(\iota (v)\) is already Pin-normalized, and its action is the familiar hyperplane reflection \[\rho _v(w)=w-2\langle v,w\rangle v.\] For orthonormal \(v,w\), the even product \(\iota (v)\iota (w)\) lies in Spin and lifts the composition \(\rho _v\rho _w\). This is the Euclidean specialization of the general Pin and paired-Spin lifting statements in Lemma [fcap-000B] and Theorem [fcap-000C].
Remark. From individual lifts to generation [lawson2016spin, I.2, Proposition 2.2, Definition 2.3, and (2.24)--(2.26), pp. 13--18] [fcap-000E]AGENTDRAFTED
Remark. From individual lifts to generation [lawson2016spin, I.2, Proposition 2.2, Definition 2.3, and (2.24)--(2.26), pp. 13--18] [fcap-000E]AGENTDRAFTED
Lawson and Michelsohn supply the twisted-adjoint reflection formula, the definitions of Pin and Spin, the description by products of normalized vectors, and the square-root obstruction to normalization. The square-witness statements in Lemma [fcap-000B] and Theorem [fcap-000C] isolate the precise algebraic hypotheses under which one or two reflections lift.
An individual lift does not by itself show that all orthogonal transformations lift. That global conclusion requires finite dimension, nondegeneracy, and the Cartan--Dieudonne factorization developed next.
From reflection generation to Pin and Spin [fcap-000U]AGENTDRAFTED
From reflection generation to Pin and Spin [fcap-000U]AGENTDRAFTED
How does reflection generation lead to the Pin and Spin groups? Starting with the Clifford algebra and its norm, we first lift orthogonal transformations and use determinant parity to select the even carrier, while the spinor norm measures the obstruction to normalization over a general field. Field extension and explicit transvections then give concrete lifts and examples of the obstruction.
Over local fields, finite-dimensional coordinates give the carriers their topologies and let us study the Spin projection and its image. For rational transformations, compatible compact-open reference subgroups provide the prerequisites for passing from these local groups to the restricted product and its away and full adelic variants.
The rational diagonal and the finite adelic spinor norm connect the rational and local pictures. We then form the finite adelic class sets and compare them under Proposition [fcap-004Q] enlargement and Proposition [fcap-004R] conjugation of the right subgroup, and under Proposition [fcap-004S] isomorphisms preserving both subgroups. Proposition [fcap-004T] distinguishes finite changes of references from equality of their product subgroups. The final leaves return to the real Spin covers.
Lemma. Fixed-subspace correction by reflections [cartan1981theory, Section 10, pp. 10--12] [fcap-000V]AGENTDRAFTED
Lemma. Fixed-subspace correction by reflections [cartan1981theory, Section 10, pp. 10--12] [fcap-000V]AGENTDRAFTED
Cartan proves reflection factorization by an induction that enlarges the fixed subspace. TauCeti formalizes the correction as a list of at most two anisotropic reflections whose product with \(g\) fixes \(W+Kx\) pointwise TauCeti.QuadraticMap.exists_reflectionOrthogonal_list_prod_mul_eqOn_sup_span_singleton. The statement below repackages that list-valued result: when \(H\) contains every reflection, closure under products places the correcting element in \(H\).
Let \(K\) be a field of characteristic different from \(2\), let \(Q\) be a quadratic form on a \(K\)-vector space \(V\), and let \(H\le O(V,Q)\) contain every reflection in a nonisotropic vector. Suppose \(g\in O(V,Q)\) fixes a subspace \(W\) pointwise and \(x\in W^{\perp }\) has \(Q(x)\ne 0\). Then there is an element \(r\in H\) such that \[rg\vert _{W+Kx}=\operatorname {id}.\] The correction leaves the previously fixed space untouched and fixes one additional nonisotropic direction. It is either one reflection or a product of two reflections.
Proof.
Proof.
Compare \(x\) with \(g(x)\). When \(g(x)-x\) is nonisotropic, reflection in that difference carries \(g(x)\) to \(x\); because the difference is orthogonal to \(W\), the reflection fixes \(W\). In the exceptional case \(g(x)+x\) is nonisotropic: reflection in this sum carries \(g(x)\) to \(-x\), and reflection in \(x\) supplies the second factor. Both factors fix \(W\), so their product gives the required correction.
Lemma. Pin-range refinement of the correction [cartan1981theory, Section 10, pp. 10--12]; [lawson2016spin, I.2, (2.26) and Theorem 2.9, pp. 18--19] [fcap-0018]
L∃∀NAGENTDRAFTED
Lemma. Pin-range refinement of the correction [cartan1981theory, Section 10, pp. 10--12]; [lawson2016spin, I.2, (2.26) and Theorem 2.9, pp. 18--19] [fcap-0018]
L∃∀NAGENTDRAFTED
Under the hypotheses of Lemma [fcap-000V], suppose moreover that \(K\) is separably closed and take \(H\) to be the range of the Pin action. Over a separably closed field, TauCeti's fixed-sign square condition from Theorem [fcap-000X] holds, so every reflection factor used by the correction has a square-normalized Pin lift by Lemma [fcap-000B]. The correcting element \(r\) can therefore be chosen in \[\operatorname {range}(\operatorname {pinToOrthogonal}),\] and still satisfies \(rg\vert _{W+Kx}=\operatorname {id}\). The statement concerns the correcting element in the Pin-action range; in the exceptional case it is the image of a product of two Pin lifts, not the image of a single reflecting vector.
Theorem. Cartan--Dieudonne generation [lawson2016spin, I.2, Theorem 2.7, p. 17] [fcap-000W]
L∃∀NAGENTDRAFTED
Theorem. Cartan--Dieudonne generation [lawson2016spin, I.2, Theorem 2.7, p. 17] [fcap-000W]
L∃∀NAGENTDRAFTED
Let \(K\) be a field of characteristic different from \(2\), let \(V\) be finite-dimensional, and let \(Q\) be nondegenerate. Every orthogonal transformation is a product of reflections in nonisotropic vectors. Equivalently, if a subgroup \(H\le O(V,Q)\) contains every such reflection, then \[H=O(V,Q).\] This formulation asserts generation only; it records neither a sharp bound on the number of reflection factors nor a parity formula for such a factorization.
Proof.
Proof.
Begin with the zero fixed subspace, whose restricted polar form is nondegenerate. If the current nondegenerate fixed subspace is not all of \(V\), its orthogonal complement is nonzero and nondegenerate, hence contains a nonisotropic vector. The correction step of Lemma [fcap-000V] enlarges the fixed subspace by that orthogonal line and preserves nondegeneracy. Finite-dimensional induction eventually makes the corrected product the identity, expressing the original transformation as a product of reflections. Cartan gives this fixed-vector induction, including the isotropic-difference case, in [cartan1981theory, Section 10, pp. 10--12].
Theorem. Surjectivity of the Pin action [lawson2016spin, I.2, Theorem 2.9, pp. 18--19] [fcap-000X]
L∃∀NAGENTDRAFTED
Theorem. Surjectivity of the Pin action [lawson2016spin, I.2, Theorem 2.9, pp. 18--19] [fcap-000X]
L∃∀NAGENTDRAFTED
Let \(K\), \(V\), and \(Q\) be as in Theorem [fcap-000W]. Suppose every scalar \(-Q(v)^{-1}\) attached to a nonisotropic vector is a square in \(K\). Then the twisted-adjoint homomorphism is surjective: \[\operatorname {pinToOrthogonal}:\operatorname {Pin}(V,Q)\twoheadrightarrow O(V,Q).\] Indeed, Lemma [fcap-000B] puts every reflection in its range, and Theorem [fcap-000W] says that those reflections generate the target. In particular the conclusion holds over a separably closed field.
Lawson and Michelsohn ask whether a nonzero vector can be rescaled to quadratic length either \(+1\) or \(-1\); see (2.26) and the discussion preceding Theorem 2.9. Under the convention \(Q=-q\), TauCeti's hypothesis asks for the particular scalar \(-Q(v)^{-1}\) to be a square, so every reflecting vector is normalized to one fixed sign. This is a sufficient and generally stronger condition, not an equivalent reformulation of Lawson--Michelsohn's condition.
Example. A planar rotation as two reflections [lawson2016spin, I.2, (2.24)--(2.26), p. 18] [fcap-000Y]AGENTDRAFTED
Example. A planar rotation as two reflections [lawson2016spin, I.2, (2.24)--(2.26), p. 18] [fcap-000Y]AGENTDRAFTED
In an oriented Euclidean plane, let \(u\) and \(v\) be unit normals whose directed angle is \(\frac {\theta }{2}\). Reflection in \(u^{\perp }\) followed by reflection in \(v^{\perp }\) is rotation through \(\theta \). With the convention \(Q=-\langle -,-\rangle \), both vectors have \(Q=-1\), and \[s=\iota (v)\iota (u)\in \operatorname {Spin}(V,Q)\] lifts that rotation. In an oriented orthonormal basis \(e_1,e_2\), the familiar rotor form is \[\pm s=\cos \left (\frac {\theta }{2}\right )+\sin \left (\frac {\theta }{2}\right )\,\iota (e_1)\iota (e_2),\] after choosing the central sign and the order convention for the two reflections. This is the two-dimensional specialization of the paired lift in Theorem [fcap-000C]; the half-angle appears because the Spin element acts by conjugation on vectors.
Lemma. Determinant parity detects the even lift [lawson2016spin, I.2, Theorems 2.7 and 2.9, pp. 17--19] [fcap-001A]
L∃∀NAGENTDRAFTED
Lemma. Determinant parity detects the even lift [lawson2016spin, I.2, Theorems 2.7 and 2.9, pp. 17--19] [fcap-001A]
L∃∀NAGENTDRAFTED
Let \(R\) be a commutative ring in which \(2\) is invertible, let \(M\) be a finite free \(R\)-module, and let \(Q\) be a quadratic form on \(M\). A reflection in a vector of invertible quadratic value has determinant \(-1\). Therefore a product of \(r\) such reflections has determinant \[(-1)^r.\] In particular, every product of an even number of reflections belongs to \(SO(M,Q)\).
Lawson--Michelsohn state this parity argument for quadratic vector spaces over a field. The finite-free commutative-ring statement above is the formalized extension: its determinant calculation uses freeness and finiteness, while invertibility of \(2\) identifies the fixed part of the grading involution with the even subalgebra.
The Clifford lift remembers this parity. If \(p\in \operatorname {Pin}(M,Q)\) and its orthogonal action has determinant \(1\), then \(p\) lies in the even Clifford subalgebra. Hence \(p\) is a Spin element. Thus any Pin lift of a special orthogonal transformation is automatically even.
Proof.
Proof.
Multiplicativity of the determinant gives the first assertion from \(\det (\rho _v)=-1\). For the second, the grading involution of a Lipschitz element is its determinant sign times that element. If the determinant is \(1\), the involution fixes the Pin element. Because \(2\) is invertible, the fixed submodule of the grading involution is precisely the even Clifford subalgebra.
Theorem. Surjectivity of the Spin action [lawson2016spin, I.2, Theorem 2.9, pp. 18--19] [fcap-001B]
Theorem. Surjectivity of the Spin action [lawson2016spin, I.2, Theorem 2.9, pp. 18--19] [fcap-001B]
Let \(K\) be a field of characteristic different from \(2\), let \(V\) be finite-dimensional, and let \(Q\) be nondegenerate. Suppose that for every nonisotropic \(v\in V\), the scalar \(-Q(v)^{-1}\) is a square in \(K\). Then the twisted-adjoint action restricts to a surjection
\[\operatorname {Spin}(V,Q)\twoheadrightarrow SO(V,Q).\]
The underlying homomorphism is CliffordAlgebra.spinToSpecialOrthogonal, and its action on vectors is the usual Spin action by CliffordAlgebra.coe_spinToSpecialOrthogonal_apply.
Indeed, the square-normalization hypothesis and Cartan--Dieudonne generation give the Pin surjection of Theorem [fcap-000X]. It lifts an element of \(SO(V,Q)\) to Pin; the lift has determinant \(1\), so Lemma [fcap-001A] shows that it is even and therefore lies in Spin. The restriction square
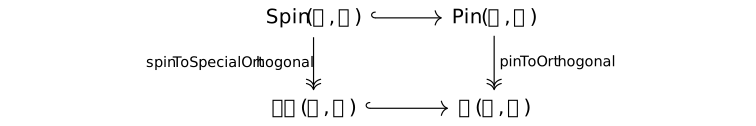
CliffordAlgebra.spinToSpecialOrthogonal_surjective_of_pinToOrthogonal_surjective.The square condition is TauCeti's fixed-sign sufficient hypothesis, stronger in general than Lawson--Michelsohn's option to normalize each vector to either sign; see Theorem [fcap-000X]. For a positive-definite real geometric form \(q\), the Clifford convention is \(Q=-q\); hence \(-Q(v)^{-1}>0\) for every nonzero \(v\), so the reflecting vectors can be normalized over \(\mathbb {R}\). This observation does not assert the square condition for arbitrary real signatures.
Proposition. The reverse norm descends through the Lipschitz action [fcap-002D]AGENTDRAFTED
Proposition. The reverse norm descends through the Lipschitz action [fcap-002D]AGENTDRAFTED
Let \(K\) be a field of characteristic different from two, let \(V\) be a positive-dimensional finite-dimensional \(K\)-space, and let \(Q\) be nondegenerate. Write \(\Gamma (Q)\) for the vector-generated Lipschitz group, and \(\tau _Q:\Gamma (Q)\to O(V,Q)\) for its twisted action. For \(x\in \Gamma (Q)\), let \(N_{\mathrm {rev}}(x)\in K^{\times }\) be the unique scalar unit satisfying \(\operatorname {rev}(x)x=N_{\mathrm {rev}}(x)\,1\). Set \(\mathcal {S}_K=K^{\times }/(K^{\times })^2\). The top row is exact, and the square commutes:
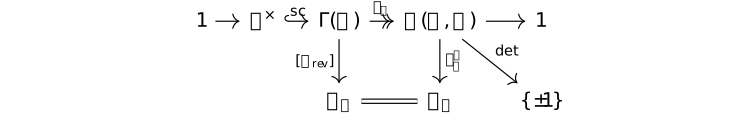
CliffordAlgebra.scalarUnits_injective
CliffordAlgebra.ker_lipschitzToOrthogonal
CliffordAlgebra.lipschitzToOrthogonal_surjective. The right
vertical map is the orthogonal spinor norm, while
\(\nu _Q=\nu _Q^O|_{SO(V,Q)}\) is its restriction used in Theorem [fcap-0023].
The square expresses descent through the action, not surjectivity of
\(\nu _Q^O\)
CliffordAlgebra.orthogonalSpinorNorm_lipschitzToOrthogonal.If \(Q(v)\) is nonzero, then
\[N_{\mathrm {rev}}(\widehat v)=Q(v),\qquad
\nu _Q^O(r_v)=[Q(v)]\]
CliffordAlgebra.cliffordNorm_unitι
CliffordAlgebra.orthogonalSpinorNorm_reflectionOrthogonal.
Consequently, for an even product
\(x=\widehat v_1\cdots \widehat v_{2k}\) of nonisotropic vector lifts,
\[\tau _Q(x)=r_{v_1}\cdots r_{v_{2k}}\in SO(V,Q),\qquad
\nu _Q(r_{v_1}\cdots r_{v_{2k}})
=\left [\prod _{i=1}^{2k}Q(v_i)\right ].\]
Multiplying a lift by \(c\in K^\times \) changes its reverse norm by \(c^2\),
so the square class is independent of the chosen lift.
[chevalley1954algebraic, II.3.5--6, pp. 52--53] gives these vector and
paired-product values. The scalar exact sequence, reflection factorization,
and the same square-scaling law appear in
[meinrenken2013clifford, Theorem 3.1, pp. 50--51].
Chevalley's quotient statement assumes positive dimension; Meinrenken works
with a finite-dimensional characteristic-zero nondegenerate bilinear space.
If \(e:(V,Q)\simeq (V',Q')\) is an isometry equivalence, then conjugation
transport preserves both norms: for \(g\in O(V,Q)\) and \(h\in SO(V,Q)\),
\[\nu _{Q'}^O(ege^{-1})=\nu _Q^O(g),\qquad
\nu _{Q'}(ehe^{-1})=\nu _Q(h).\]
It therefore carries \(\ker \nu _Q\) onto \(\ker \nu _{Q'}\)
QuadraticMap.IsometryEquiv.orthogonalSpinorNorm_orthogonalGroupCongr
QuadraticMap.IsometryEquiv.spinorNorm_specialOrthogonalGroupCongr
kernel-transport source.
The induced kernel equivalence also commutes with Spin transport
Spin-transport source.
These are isometry-equivalence statements; they do not assert scalar-extension
or orthogonal-product naturality. This is the norm-square companion to the
vector-action square in Proposition [fcap-0029].
Theorem. The Spin image is the spinor-norm kernel [fcap-0023]
L∃∀NAGENTDRAFTED
Theorem. The Spin image is the spinor-norm kernel [fcap-0023]
L∃∀NAGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible, \(V\) a
finite-dimensional \(K\)-space, and \(Q\) a nondegenerate quadratic form.
The Clifford norm of a Lipschitz lift, taken modulo squares, descends to
\(\nu _Q^O:O(V,Q)\to K^{\times }/(K^\times )^2\)
CliffordAlgebra.orthogonalSpinorNorm_lipschitzToOrthogonal.
Its restriction to \(SO(V,Q)\) is the spinor norm
\(\nu _Q:SO(V,Q)\to K^\times / (K^\times )^2\)
CliffordAlgebra.spinorNorm. Then
\[\operatorname {im}\bigl (\operatorname {Spin}(V,Q)\to SO(V,Q)\bigr )
=\ker \nu _Q.\]
Thus a special orthogonal transformation has a Spin lift exactly
when its spinor-norm class is trivial.
[chevalley1954algebraic, II.3.5--6, pp. 52--53] defines the
reversal norm and describes the reduced orthogonal image by square
classes of products \(Q(u)Q(v)\). His ordinary Clifford action and
reversal norm compare with TauCeti's twisted action on even lifts: grading
fixes such lifts, so the two actions agree, and reverse and star norms
coincide Remark [fcap-0028]. For a single nonisotropic reflection, the descended
orthogonal spinor norm is
\[\nu _Q^O(r_v)=[Q(v)]\]
CliffordAlgebra.orthogonalSpinorNorm_reflectionOrthogonal.
This agrees with Chevalley's reverse norm. TauCeti's star norm on the odd
vector lift has class \([-Q(v)]\); it is a different norm. The extra minus
sign cancels on an even product, where the reverse and star norms agree.
Proof.
Proof.
Every Spin element has reverse norm one, so its image has trivial
spinor norm
CliffordAlgebra.spinorNorm_spinToSpecialOrthogonal.
Conversely, suppose first that \(V\) has positive dimension. Take
\(g\in SO(V,Q)\) with \(\nu _Q(g)=1\), and choose a Lipschitz lift \(x\) of
\(g\). Since \(\det (g)=1\), determinant parity first shows that
\(x\) is even
CliffordAlgebra.mem_even_of_det_lipschitzToOrthogonal_eq_one
Lemma [fcap-001A]. Trivial spinor class says that
\(N_{\mathrm {rev}}(x)\) is a square. Scalar normalization therefore produces
an even lift with reverse norm one
source theorem;
by the even-element comparison in Remark [fcap-0028], it lies in Spin and has
the same orthogonal action. In dimension zero \(SO(V,Q)\) is trivial, so the
image and the spinor-norm kernel are both its identity subgroup.
Theorem. Spinor norms commute with extension of scalars [fcap-003N]AGENTDRAFTED
Theorem. Spinor norms commute with extension of scalars [fcap-003N]AGENTDRAFTED
Let \(L/K\) be an extension of fields of characteristic different from two. Let \(V\) be a positive-dimensional finite-dimensional \(K\)-space, and let \(Q\) be nondegenerate. Set \(V_L=L\otimes _K V\), with extended form \(Q_L\), and write \[j:K^{\times }/(K^\times )^2\longrightarrow L^{\times }/(L^\times )^2, \qquad j([a]_K)=[a]_L.\] For \(g\in O(V,Q)\), scalar extension gives \(g_L(a\otimes v)=a\otimes g(v)\). Then \[\nu _{Q_L}^O(g_L)=j\bigl (\nu _Q^O(g)\bigr ).\] In particular, for \(g\in SO(V,Q)\), \[\nu _{Q_L}(g_L)=j\bigl (\nu _Q(g)\bigr ),\] and \(g_L\) has a Spin lift exactly when \(j(\nu _Q(g))=1\).
Proof.
Proof.
A Gram matrix for the unhalved polar form \(B_Q\) has nonzero determinant. Its determinant remains nonzero under the field embedding, so \(Q_L\) is nondegenerate. For \(Q(v)\ne 0\), the reflection formula is \[r_v(x)=x-\frac {B_Q(x,v)}{Q(v)}v.\] Since \(Q_L(1\otimes v)=Q(v)\) and the polar form extends by \(L\)-bilinearity, this formula on pure tensors gives \((r_v)_L=r_{1\otimes v}\). Cartan--Dieudonne writes any orthogonal \(g\) as \(r_{v_1}\cdots r_{v_k}\). The reflection values from Proposition [fcap-002D] therefore give \[\begin {aligned} \nu _{Q_L}^O(g_L) &=\left [\prod _{i=1}^k Q_L(1\otimes v_i)\right ]_L\\ &=j\left (\left [\prod _{i=1}^k Q(v_i)\right ]_K\right ) =j\bigl (\nu _Q^O(g)\bigr ). \end {aligned}\] Determinants also extend, so restricting to \(SO\) proves the second identity. Apply the image/kernel theorem Theorem [fcap-0023] over \(L\) to obtain the lifting criterion.
The Clifford map \(c:\mathcal {C}\kern -2pt\ell (Q)\to \mathcal {C}\kern -2pt\ell (Q_L)\) sends \(\iota _Q(v)\) to \(\iota _{Q_L}(1\otimes v)\). It preserves parity, reversal and products, and carries each nonisotropic vector unit to a nonisotropic vector unit. Thus it restricts to a map of the actual Spin carriers, and their vector actions satisfy \[q_L(c(s))=(q_K(s))_L\qquad (s\in \operatorname {Spin}(Q)),\] where \(q_K\) and \(q_L\) denote the Spin projections. Indeed, apply \(c\) to the conjugation identity on every vector generator. A lift defined over \(K\) therefore remains a lift over \(L\); the next proposition explains how additional lifts can appear when \(j\) kills a nontrivial square class.
[chevalley1954algebraic, Section 2.7, pp. 60--61] describes the Clifford extension, compatibility with the main antiautomorphism, and the group/vector-action inclusions in even dimension. His main antiautomorphism is reversal. The reflection proof above gives the stated naturality in every positive dimension, using the reverse-norm convention of Proposition [fcap-002D].
TauCeti proves the orthogonal and special-orthogonal identities in
CliffordAlgebra.orthogonalSpinorNorm_orthogonalGroupBaseChange
and
CliffordAlgebra.spinorNorm_specialOrthogonalGroupBaseChange
under the field, finite-dimensionality, nondegeneracy and invertibility-of-two
hypotheses. The commuting Spin-action square is
CliffordAlgebra.spinToSpecialOrthogonal_baseChange;
its more general input is a finite free module over a commutative ring
with two invertible.
Proposition. Spin lifts over a quadratic extension [fcap-003O]AGENTDRAFTED
Proposition. Spin lifts over a quadratic extension [fcap-003O]AGENTDRAFTED
Keep the quadratic-space hypotheses of Theorem [fcap-003N]. Let \(d\in K^\times \) be nonsquare, put \(L=K(\sqrt d)\), and let \(\sigma \) be its nontrivial \(K\)-automorphism. The square-class map has kernel \[\ker j=\{1,[d]_K\}.\] Consequently, for \(g\in SO(V,Q)\), \[g_L\text { has a Spin lift} \quad \Longleftrightarrow \quad \nu _Q(g)\in \{1,[d]_K\}.\] The trivial class already gives a lift over \(K\). If \(\nu _Q(g)=[d]_K\), the two lifts over \(L\) are exchanged by \(\sigma \); neither is the scalar extension of a \(K\)-defined Spin element.
Proof.
Proof.
Suppose \(a\in K^\times \) becomes a square in \(L\). Write \[a=(u+v\sqrt d)^2=u^2+dv^2+2uv\sqrt d, \qquad u,v\in K.\] The basis \(1,\sqrt d\) and characteristic different from two give \(uv=0\). If \(v=0\), then \(a=u^2\); if \(u=0\), then \(a=dv^2\). The nonzero remaining coefficient shows that \([a]_K\) is respectively \(1\) or \([d]_K\). Both classes become squares in \(L\), and they are distinct because \(d\) is nonsquare. This proves the kernel formula; Theorem [fcap-003N] gives the criterion for \(g_L\).
Now assume \(\nu _Q(g)=[d]_K\). By Proposition [fcap-002D], take a Lipschitz lift \(x\) of \(g\); determinant parity makes it even. Its reverse norm is \(db^2\) for some \(b\in K^\times \). Replacing \(x\) by \(x/b\) preserves its action and makes \(N_{\mathrm {rev}}(x)=d\). In the extended Clifford algebra set \[s=\frac {c(x)}{\sqrt d}.\] Scalar units are Lipschitz and even by Proposition [fcap-002D]. Thus \(s\) is even and Lipschitz, and \[N_{\mathrm {rev}}(s)=\frac {d}{(\sqrt d)^2}=1.\] The carrier criterion Remark [fcap-0028] places \(s\) in the actual \(\operatorname {Spin}(Q_L)\), and scalar normalization leaves its vector action equal to \(g_L\). Any other Spin lift differs from \(s\) by a scalar unit, by the Lipschitz action kernel over \(L\). Norm one forces that scalar's square to be one, so all lifts are precisely \(s\) and \(-s\).
The coefficient automorphism \(\sigma \) acts semilinearly on \(\mathcal {C}\kern -2pt\ell (Q_L)\): it fixes each extended generator and sends \(\sqrt d\) to \(-\sqrt d\). In particular it fixes \(c(x)\) and gives \[\sigma (s)=-s,\qquad \sigma (-s)=s.\] These elements are distinct because \(s\) is a unit and the characteristic is not two. Every Clifford element obtained by extending coefficients from \(K\) is fixed by \(\sigma \). Neither lift can therefore come from \(\operatorname {Spin}(Q)\), in agreement with its nontrivial spinor-norm obstruction.
For an explicit rational example, take \(K=\mathbb Q\) and \[Q(ae+bf)=a^2+2b^2,\qquad g=-\operatorname {Id}=r_e r_f.\] Here \(e^2=1\), \(f^2=2\), and \(ef=-fe\). Thus \(x=ef\) satisfies \[\operatorname {rev}(x)x=feef=2,\qquad x^2=efef=-2,\] and \(\nu _Q(g)=[2]_{\mathbb Q}\) is nontrivial. Over \(L=\mathbb Q(\sqrt 2)\), however, \[s=\frac {ef}{\sqrt 2},\qquad N_{\mathrm {rev}}(s)=1,\qquad s^2=-1.\] Its vector action is still \(-\operatorname {Id}\). The two Spin lifts \(s,-s\) are interchanged by conjugating \(\sqrt 2\); the rational orthogonal transformation acquires lifts without either lift becoming rational.
Proposition. Eichler transvections have additive Spin lifts [fcap-002M]AGENTDRAFTED
Proposition. Eichler transvections have additive Spin lifts [fcap-002M]AGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible, let \(V\) be a
\(K\)-space, and let \(Q\) be nondegenerate. Write \(B_Q\) for the unhalved
polar form and \(\widehat v=\iota _Q(v)\) for a Clifford generator. Suppose
\[Q(u)=0,\qquad B_Q(u,w)=0.\]
The Eichler transvection and its Clifford lift are
\[\begin {aligned}
E_{u,w}(x)
&=x+B_Q(x,u)w-B_Q(x,w)u-Q(w)B_Q(x,u)u,\\
L_{u,w}&=1+\widehat w\widehat u.
\end {aligned}\]
Then \(L_{u,w}\in \operatorname {Spin}(Q)\), its Spin action is \(E_{u,w}\), and
\[L_{u,w}^{-1}=\operatorname {rev}(L_{u,w})=1-\widehat w\widehat u.\]
The formal transformation formula already makes sense over a commutative
ring and module, without nondegeneracy or invertible \(2\)
QuadraticMap.transvection_apply
QuadraticMap.transvection_mem_specialOrthogonalGroup.
The actual Spin lift uses the field, invertible-two, and nondegeneracy
hypotheses stated above
CliffordAlgebra.coe_spinTransvection
CliffordAlgebra.coe_spinToSpecialOrthogonal_spinTransvection.
Indeed, put \(N=\widehat w\widehat u\). The Clifford relations give \[\begin {gathered} N^2=0,\qquad \operatorname {rev}(N)=-N,\\ N\widehat x-\widehat xN =B_Q(x,u)\widehat w-B_Q(x,w)\widehat u,\\ N\widehat xN=Q(w)B_Q(x,u)\widehat u. \end {gathered}\] Thus expansion of \((1+N)\widehat x(1-N)\) gives exactly the displayed formula, including its negative quadratic term, and proves reverse norm one. Actual membership in the vector-generated carrier is a separate point. If \(Q(w)\ne 0\), the explicit factorization is \[1+\widehat w\widehat u =\widehat {\frac {w}{Q(w)}}\, \widehat {\bigl (w+Q(w)u\bigr )},\] and the two quadratic values multiply to \(1\). If \(Q(w)=0\) and \(w\notin Ku\), nondegeneracy supplies \(x\perp u\) with \(b=B_Q(w,x)\ne 0\). For \[a=x+\frac {b-Q(x)}{b}w\] one has \(Q(a)=b\), \(Q(w+a)=2b\), and \(L_{u,w}=L_{u,w+a}L_{u,-a}\), reducing to the nonisotropic case. If \(w\in Ku\), the lift is \(1\). This is the algebraic carrier argument behind the linked formal construction; it needs no finite-dimensionality.
For \(w,w'\in u^\perp \), the cross term
\((\widehat w\widehat u)(\widehat {w'}\widehat u)\) vanishes. Hence
\[L_{u,w+w'}=L_{u,w}L_{u,w'},\qquad
L_{u,-w}=L_{u,w}^{-1},\qquad
L_{u,w+cu}=L_{u,w}.\]
The same equations hold after projection to the Eichler transformations.
Thus the lifts form a homomorphism
\[u^{\perp }/Ku\longrightarrow \operatorname {Spin}(Q)\]
which commutes with the projection to \(SO(Q)\); when \(u\ne 0\), it is
injective
CliffordAlgebra.spinTransvection_add
CliffordAlgebra.spinTransvection_add_smul
CliffordAlgebra.spinToSpecialOrthogonal_comp_transvectionLiftHom
CliffordAlgebra.transvectionLiftHom_injective.
The domain is \(u^{\perp }/Ku\), not all of \(V/Ku\); for \(u=0\) the family is
trivial. If \(V\) is additionally finite-dimensional, these transformations
have trivial spinor norm, as predicted by Theorem [fcap-0023]
CliffordAlgebra.spinorNorm_transvection.
Chevalley treats the common totally singular case \(Q(u)=Q(w)=B_Q(u,w)=0\): his finite exponential is \(1+\widehat w\widehat u\) and his conjugation formula is the displayed action with its quadratic term zero [chevalley1954algebraic, III.1.7, pp. 73--74]. This passage does not state the arbitrary-\(Q(w)\) formula. Meinrenken's quantization of the bivector \(w\wedge u\) is \(\widehat w\widehat u\); his commutator theorem and exponential Spin comparison recover the full formula over finite-dimensional nondegenerate real or complex spaces [meinrenken2013clifford, Section 2.2.10, Theorem 2.1 and Proposition 2.12, pp. 39--40] [meinrenken2013clifford, Proposition 3.2, pp. 53--54]. Here his symmetric form is the half-polar form \(B_M=b_Q=B_Q/2\). Since \(N^2=0\), both the Clifford and vector exponentials truncate, and the written polynomial calculation fixes the normalization and extends the formula to the stated general field. No claim that every Spin element is one exponential is made.
Example. A null-frame Spin transvection and a radical shear [fcap-002N]AGENTDRAFTED
Example. A null-frame Spin transvection and a radical shear [fcap-002N]AGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible and take the
three-dimensional quadratic space
\[Q(au+bv+cz)=ab+c^2.\]
Thus \(u,v\) are null, \(B_Q(u,v)=1\), \(Q(z)=1\), and \(z\) is orthogonal to
their hyperbolic plane. For \(w=tz\), the preceding lift and action become
\[\begin {gathered}
L_t=1+t\widehat z\widehat u
=\widehat z\,\widehat {(z+tu)},\\
E_t(u)=u,\qquad E_t(z)=z-2tu,\qquad
E_t(v)=v+tz-t^2u.
\end {gathered}\]
Both factors in the displayed product have quadratic value \(1\). Hence the
pair criterion puts \(L_t\) directly in the actual Spin group, including at
\(t=0\)
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
In coordinates \((a,c,b)\) the transformation is
\[E_t=
\begin {pmatrix}
1&-2t&-t^2\\
0&1&t\\
0&0&1
\end {pmatrix}.\]
Substitution gives \(Q(E_t x)=Q(x)\), while multiplication gives
\(E_sE_t=E_{s+t}\) and \(L_sL_t=L_{s+t}\). At \(t=1/2\),
\[z\longmapsto z-u,\qquad
v\longmapsto v+\frac 12z-\frac 14u,\]
and composing this map with itself gives
\(z\mapsto z-2u\) and \(v\mapsto v+z-u\). For \(t\ne 0\), the vector action has
\((E_t-1)^2v=-2t^2u\) and \((E_t-1)^3=0\), although the Clifford increment
satisfies \((L_t-1)^2=0\). Over \(\mathbb R\), this is the null frame inside
the split model of Example [fcap-002I]; over every stated field it is a concrete
element of the spinor-norm kernel in Theorem [fcap-0023].
There is also a precise radical comparison. On the degenerate real form \[Q_{\mathrm {PGA}}(ar+xe+yf)=x^2+y^2\] the line \(\mathbb Rr\) is radical. With \(u=r\) and \(w=te\), the same ring-level transvection formula gives \[\begin {gathered} L_t=1+t\widehat e\widehat r =\widehat e\,\widehat {(e+tr)},\\ E_t(r)=r,\qquad E_t(e)=e-2tr,\qquad E_t(f)=f. \end {gathered}\] The nondegenerate packaged Spin-transvection theorem does not apply here. Nevertheless this particular lift still belongs to the vector-generated Spin carrier, because both displayed factors have quadratic value \(1\); the pair criterion itself needs no nondegeneracy. The quadratic action term vanishes because \(B_Q(r,-)=0\), and now \((E_t-1)^2=0\). This retains the original degenerate Clifford algebra rather than replacing it by the radical quotient of Remark [fcap-002C]. It does not identify the shear with a particular PGA point translation, motor parameter, dual encoding, or orientation convention.
Example. A mixed-sign isometry has no norm-one Spin lift [fcap-002E]AGENTDRAFTED
Example. A mixed-sign isometry has no norm-one Spin lift [fcap-002E]AGENTDRAFTED
On \(\mathbb R^2\), let \(Q(a,b)=a^2-b^2\), \(e_+=(1,0)\), and \(e_-=(0,1)\). The corresponding reflections are \[r_{e_+}=\operatorname {diag}(-1,1),\qquad r_{e_-}=\operatorname {diag}(1,-1),\] so \(g=r_{e_+}r_{e_-}=-I\) lies in \(SO(Q)\). Its spinor norm is \[\nu _Q(g)=[Q(e_+)Q(e_-)]=[-1]\ne [1].\] With the two norm conventions of Remark [fcap-0028], the even Clifford lift \(x=\widehat e_+\widehat e_-\) has \[N_{\mathrm {rev}}(x)=N_*(x)=-1.\] For every \(c\in \mathbb R^\times \), the scalar multiple \(cx\) has norm \(-c^2\), which cannot equal \(1\). More generally, any two Lipschitz lifts of \(g\) differ by a scalar by Proposition [fcap-002D], so no lift can be normalized into the norm-one Spin carrier. Equivalently, the image theorem in Theorem [fcap-0023] excludes a Spin lift because \(\nu _Q(g)\) is nontrivial.
This is the mixed-sign counterpart to the successful square normalizations in Lemma [fcap-000B] and Theorem [fcap-000C]. Meinrenken notes that over \(\mathbb R\) one sometimes uses the weaker carrier condition \(N(x)=\pm 1\); under that different convention this \(x\) passes the norm test [meinrenken2013clifford, Remark 3.2, p. 52]. TauCeti's Spin group uses the norm-one carrier, so the two conventions must not be identified.
Remark. Real spinor-norm images and the low-rank boundary [fcap-002F]AGENTDRAFTED
Remark. Real spinor-norm images and the low-rank boundary [fcap-002F]AGENTDRAFTED
Let \(Q\) be a positive-dimensional finite-dimensional nondegenerate real
quadratic form. Distinguish the orthogonal norm \(\nu _Q^O\) on \(O(Q)\) from
its restriction \(\nu _Q\) to \(SO(Q)\). Since
\(\mathbb R^{\times }/(\mathbb R^\times )^2=\{[1],[-1]\}\), their images and the
Spin image are:
\[\begin {array}{c|c|c|c}
\text {case}&\operatorname {im}\nu _Q^O&
\operatorname {im}\nu _Q&\text {Spin image}\\ \hline
\text {positive definite}&\{[1]\}&\{[1]\}&SO(Q)\\
\text {negative definite}&\{[1],[-1]\}&\{[1]\}&SO(Q)\\
\text {indefinite}&\{[1],[-1]\}&\{[1],[-1]\}&\ker \nu _Q
\end {array}\]
For a positive form, every reflected value is a square, so the orthogonal
norm is trivial
CliffordAlgebra.orthogonalSpinorNorm_eq_one_of_posDef. For
a negative form, the orthogonal norm is the determinant square class and is
therefore trivial on \(SO(Q)\)
CliffordAlgebra.orthogonalSpinorNorm_eq_orthogonalDetSquareClass_of_negDef
CliffordAlgebra.spinorNorm_eq_one_of_negDef. In the
indefinite case, one positive and one negative reflection give a
determinant-one element of norm \([-1]\), so \(\nu _Q\) is onto
CliffordAlgebra.spinorNorm_surjective_of_indefinite. Thus
the final kernel has index two. The Spin-image column follows from
Theorem [fcap-0023]; the table does not identify this kernel with a topological
component.
Rank zero is separate: \(SO(Q)\) is trivial, and the image/kernel theorem
uses its subsingleton branch rather than the positive-dimensional scalar row.
In rank one, \(SO(Q)\) and its spinor norm are trivial. For any nonzero \(v\),
the image of \(\nu _Q^O\) is generated by \([Q(v)]\), and it is trivial exactly
when \(Q(v)\) is a square
CliffordAlgebra.spinorNorm_eq_one_of_finrank_le_one
CliffordAlgebra.orthogonalSpinorNorm_range_eq_zpowers_of_finrank_eq_one
CliffordAlgebra.orthogonalSpinorNorm_eq_one_iff_isSquare_apply_of_finrank_eq_one.
An indefinite real form has rank at least two. Degenerate or semidefinite PGA
forms lie outside every row of this nondegenerate table.
Theorem. Spin acts transitively on a positive quadratic sphere [fcap-0024]
L∃∀NAGENTDRAFTED
Theorem. Spin acts transitively on a positive quadratic sphere [fcap-0024]
L∃∀NAGENTDRAFTED
Let \(V\) be a finite-dimensional real vector space with \(\dim V\geq 2\), and let \(Q\) be positive definite. If \(Q(x)=Q(y)=c>0\), then some \(s\in \operatorname {Spin}(Q)\) satisfies \[\operatorname {spinVectorAction}_Q(s,x)=y.\] In particular, Spin acts transitively on the unit level \(Q(v)=1\). This is a statement about the algebraic vector action; no topology or compactness is needed.
Cartan's anisotropic-normal reflection has determinant \(-1\) [cartan1981theory, Section 9, pp. 9--10]. His even-reflection correction appears in [cartan1981theory, Section 10, p. 10]. The following two-case calculation gives the sphere orbit explicitly.
Proof.
Proof.
Write \(B_Q\) for the polar form. For \(a\ne 0\), reflection in the
hyperplane perpendicular to \(a\) is
\[r_a(v)=v-\frac {B_Q(a,v)}{Q(a)}a.\]
If \(x+y\ne 0\), then positive definiteness makes \(x+y\) anisotropic,
and
\[Q(x+y)=2c+B_Q(x,y)=B_Q(x+y,x).\]
Hence \(r_{x+y}(x)=-y\) and \(r_y r_{x+y}(x)=y\). If \(y=-x\), choose a
nonzero \(z\) with \(B_Q(z,x)=0\), possible because \(\dim V\geq 2\). Then
\(r_z(x)=x\) and \(r_x r_z(x)=y\). Both maps are products of two
reflections, so they lie in \(SO(Q)\). The positive-definite surjectivity
CliffordAlgebra.spinToSpecialOrthogonal_surjective_of_posDef
lifts the chosen map to Spin, whose vector action is the same map.
The formal surjectivity theorem uses positive \(Q\) directly: every
nonzero value \(Q(v)\) has a real square root, making the spinor norm
trivial on \(SO(Q)\)
CliffordAlgebra.orthogonalSpinorNorm_eq_one_of_posDef.
This is a separate route from the fixed-sign
sufficient hypothesis in Theorem [fcap-001B].
Lemma. The real Spin kernel is the scalar pair [gallier2014clifford, Section 1.8, Proposition 1.21, pp. 39--40] [fcap-001C]
L∃∀NAGENTDRAFTED
Lemma. The real Spin kernel is the scalar pair [gallier2014clifford, Section 1.8, Proposition 1.21, pp. 39--40] [fcap-001C]
L∃∀NAGENTDRAFTED
For a real quadratic space of signature \((p,q)\) with \(p+q>0\), the kernel of the Spin action is the scalar pair: \[(\mathbb Z/2\mathbb Z)_{\mathrm {mult}} \simeq \ker \bigl (\operatorname {Spin}(p,q)\longrightarrow SO(p,q)\bigr ).\] The nontrivial residue class maps to the scalar Clifford element \(-1\). Thus the two kernel elements are precisely \(1\) and \(-1\). This is the kernel used in Gallier's real double-cover theorem.
TauCeti proves the analogous algebraic statement over a field \(K\): \(V\) is nontrivial and finite-dimensional, \(Q\) is nondegenerate, and \(2\) is invertible in \(K\). Under exactly those hypotheses it constructs the displayed canonical multiplicative equivalence. This is a generalization of the cited real result, not an attribution of arbitrary-field kernel classification to Gallier.
Theorem. The algebraic Spin extension [meinrenken2013clifford, Definition 3.2, pp. 51--52] [fcap-001D]
L∃∀NAGENTDRAFTED
Theorem. The algebraic Spin extension [meinrenken2013clifford, Definition 3.2, pp. 51--52] [fcap-001D]
L∃∀NAGENTDRAFTED
Let \(K\) be a characteristic-zero field, let \(V\) be nonzero and
finite-dimensional, and let its bilinear form be nondegenerate. Meinrenken defines Spin as the
even part of the norm-one Clifford group. Its kernel is the scalar pair. If
the Spin action is surjective, these data form the group extension
\[1\longrightarrow (\mathbb Z/2\mathbb Z)_{\mathrm {mult}}
\longrightarrow \operatorname {Spin}(Q)\longrightarrow SO(Q)\longrightarrow 1.\]
The left map sends the nontrivial class to \(-1\); the right map is the Spin
action. TauCeti packages this generic construction from an explicit
surjectivity proof. The group-extension constructor used in that package is
GroupExtension.ofMulEquivKer.
Meinrenken warns that the map to \(SO(V)\) need not be surjective over a general field; it is surjective when every element of \(K\) has a square root, because lifts can then be rescaled to have norm one. TauCeti separates this issue explicitly. Its generic construction assumes a field, a nontrivial finite-dimensional module, invertible \(2\), a nondegenerate quadratic form, and a supplied surjectivity proof. Over a separably closed field, Theorem [fcap-001B] supplies that proof and yields the specialized extension.
Lemma. The real Pin kernel is the scalar pair [gallier2014clifford, Section 1.8, Proposition 1.21, pp. 39--40] [fcap-001E]
L∃∀NAGENTDRAFTED
Lemma. The real Pin kernel is the scalar pair [gallier2014clifford, Section 1.8, Proposition 1.21, pp. 39--40] [fcap-001E]
L∃∀NAGENTDRAFTED
For a real quadratic space of signature \((p,q)\) with \(p+q>0\), the Pin action has the same two-element kernel: \[(\mathbb Z/2\mathbb Z)_{\mathrm {mult}} \simeq \ker \bigl (\operatorname {Pin}(p,q)\longrightarrow O(p,q)\bigr ).\] Its nontrivial generator is the image in Pin of the scalar Spin element \(-1\). The identification is obtained by comparing the Pin kernel with the Spin kernel, not by adding a second pair of central elements. Gallier's real double-cover proof uses exactly the quotient by \(\{\pm 1\}\).
TauCeti transports the Spin-kernel equivalence to Pin over a field \(K\) when the module is nontrivial and finite-dimensional, \(Q\) is nondegenerate, and \(2\) is invertible. These are the formal theorem's exact assumptions; the cited scholarly claim is the real case.
Theorem. The algebraic Pin extension [meinrenken2013clifford, Definition 3.2, pp. 51--52] [fcap-001F]
L∃∀NAGENTDRAFTED
Theorem. The algebraic Pin extension [meinrenken2013clifford, Definition 3.2, pp. 51--52] [fcap-001F]
L∃∀NAGENTDRAFTED
In Meinrenken's characteristic-zero, nonzero, finite-dimensional, nondegenerate setting, Pin is the kernel of the norm on the Clifford group. Its scalar kernel and any proof that the Pin action is surjective determine the group extension \[1\longrightarrow (\mathbb Z/2\mathbb Z)_{\mathrm {mult}} \longrightarrow \operatorname {Pin}(Q)\longrightarrow O(Q)\longrightarrow 1.\] The inclusion sends the nontrivial class to the scalar \(-1\), and the projection is the Pin action. Meinrenken notes that surjectivity can fail over a general field and that square roots for all field elements suffice to normalize lifts. TauCeti's generic theorem instead assumes a field, a nontrivial finite-dimensional module, invertible \(2\), a nondegenerate quadratic form, and an explicit surjectivity proof. Its separably closed specialization obtains that proof from the formal Cartan--Dieudonne route.
Proposition. Isometries transport the Spin vector action [fcap-0029]
L∃∀NAGENTDRAFTED
Proposition. Isometries transport the Spin vector action [fcap-0029]
L∃∀NAGENTDRAFTED
Let \(R\) be a commutative ring, let \(M_1,M_2\) be \(R\)-modules with
quadratic forms \(Q_1,Q_2\), and let \(f:M_1\to M_2\) be an \(R\)-linear map
satisfying
\[Q_2(f(m))=Q_1(m).\]
The Clifford universal property gives an algebra homomorphism
\(\operatorname {Cl}(f):\mathcal {C}\kern -2pt\ell (Q_1)\to \mathcal {C}\kern -2pt\ell (Q_2)\) characterized on generators by
\[\operatorname {Cl}(f)(\iota _{Q_1}(m))=\iota _{Q_2}(f(m))\]
CliffordAlgebra.map_apply_ι.
It preserves the Spin carrier and therefore restricts to a group homomorphism
\(\operatorname {Spin}(f):\operatorname {Spin}(Q_1)\to \operatorname {Spin}(Q_2)\)
QuadraticMap.Isometry.spinGroupMap. Concretely, the
Clifford map preserves Lipschitz membership
QuadraticMap.Isometry.map_mem_lipschitzGroup, evenness
CliffordAlgebra.map_mem_even, and Clifford conjugation
CliffordAlgebra.map_star; these are the carrier conditions
separated in Remark [fcap-0028]. Neither construction requires \(f\) to have an
inverse.
Now suppose that \(2\) is invertible in \(R\). If \(a_i\) denotes the Spin
vector action on \(M_i\), then
\[a_2\bigl (\operatorname {Spin}(f)(s),f(m)\bigr )
=f\bigl (a_1(s,m)\bigr ).\]
This identity says that the square with horizontal maps \(a_1,a_2\) and
vertical maps \(\operatorname {Spin}(f)\times f,f\) commutes. It is the vector-action
naturality equation, with no finite-dimensionality or nondegeneracy
hypothesis. If \(f\) is instead an isometry equivalence, it induces a Spin
equivalence
QuadraticMap.IsometryEquiv.spinGroupEquiv, and the same
square packages as naturality of the Spin-to-special-orthogonal homomorphism
source theorem.
A changed Gram matrix shows why the target form is part of the data. Over \(\mathbb Q\), set \(Q_1(x,y)=x^2+y^2\) and \(T(x,y)=(2x,y)\). Keeping the same form on the target does not give an isometry: at \(e_1\), \[Q_1(Te_1)=4\ne 1=Q_1(e_1).\] Correspondingly, the source generator \(\iota _{Q_1}(e_1)\) squares to \(1\), while its proposed image \(\iota _{Q_1}(2e_1)\) squares to \(4\); that assignment cannot define the claimed Clifford map.
For the transported target form \(Q_2(x,y)=x^2/4+y^2\), one has \(Q_2(Tv)=Q_1(v)\). In column coordinates, \[G_1=I,\qquad G_2=(T^{-1})^\top G_1T^{-1} =\begin {pmatrix}1/4&0\\0&1\end {pmatrix},\qquad T^\top G_2T=G_1.\] Now \(\iota _{Q_2}(2e_1)^2=Q_2(2e_1)=1\), so the generator relation is preserved. Thus an arbitrary basis scaling is not a fixed-form isometry; it becomes an isometry only after the domain and target forms are related in the correct direction. This differs from the module equivalence \(T_Q:\mathcal {C}\kern -2pt\ell (Q)\simeq \bigwedge M\) in Lemma [fcap-0004], which is not an algebra map.
Meinrenken derives \(\operatorname {Cl}(f)\) from the same universal property for a bilinear-form-preserving linear map [meinrenken2013clifford, Section 2.2.2, Proposition 2.2, p. 29]. Chevalley's tensor-quotient construction gives the corresponding extension from generator images whose squares are \(Q(x)\) [chevalley1954algebraic, II.1.1, pp. 38--39]. In Meinrenken's convention \(Q(v)=B(v,v)\), so his \(B\) is the half-polar form \(b_Q\) of Convention [fcap-0027]. These sources work over finite-dimensional vector spaces over fields; Meinrenken assumes characteristic different from two. The formal action square above has the commutative-ring hypotheses stated here. This card makes no claim about scalar extension, orthogonal sums, or composition of extension maps.
Definition. The canonical topology on local points [fcap-0044]AGENTDRAFTED
Definition. The canonical topology on local points [fcap-0044]AGENTDRAFTED
Here a local field \(K\) of characteristic different from \(2\) means \(\mathbb R\) or \(\mathbb C\) with its usual topology, or a complete discretely valued field with finite residue field and \(\operatorname {char}K\ne 2\), with its valuation topology. The last case includes finite extensions of \(\mathbb Q_2\): the characteristic restriction is on \(K\), not its residue field. This uses the nonarchimedean definition in [lam2005quadratic, VI.2, Definition 2.1 and the discussion, pp. 151--152], with the two archimedean fields included explicitly.
For a finite-dimensional \(K\)-vector space \(W\), its canonical topology is the topology transported from \(K^d\) by any basis, where \(d=\dim _K W\). It is independent of the basis: a change of coordinates and its inverse have entries that are finite linear combinations, hence are continuous. In dimension zero this gives the one-point topology. Every linear map between such spaces is continuous by the same argument.
More generally, the canonical topology on the local points of an affine algebraic set is the subspace topology in any finite coordinate presentation. Explicitly, let \(X(K)\) consist of the points \(x\in K^m\) satisfying the finite polynomial equations \[\begin {gathered} f_i(x)=0\\ (i=1,\ldots ,r). \end {gathered}\] Give \(X(K)\) the topology inherited from \(K^m\). Changing the finite algebraic presentation expresses each new coordinate as a polynomial in the old ones and conversely. Both coordinate maps are continuous, so this topology is independent of the presentation. This is the concrete affine construction in [conrad2011adelic, Proposition 2.1 and its proof, p. 2]. It also shows directly that polynomial maps on local points are continuous.
Let \(A\) be a finite-dimensional unital \(K\)-algebra, with its canonical vector-space topology. Its multiplication is continuous because its coordinates are bilinear polynomials. On the group of units \(A^\times \), the affine-point construction first gives the inverse-graph topology: \[\begin {gathered} A^\times \longrightarrow A\times A,\\ x\longmapsto (x,x^{-1}). \end {gathered}\] This identifies the units with the solution set of \(xy=yx=1\). The inverse coordinate matters in the general topological-ring construction; see [conrad2011adelic, opening of Section 3, pp. 3--4].
Over the local fields specified above, this is also the subspace topology from \(A\). Indeed, write \(L_x\) for the matrix of left multiplication by \(x\). Its entries depend linearly on \(x\), and for a unit \(x\), \[\begin {gathered} x^{-1}=L_x^{-1}(1),\\ L_x^{-1}=\frac {\operatorname {adj}(L_x)}{\det L_x}. \end {gathered}\] Polynomial continuity and continuity of reciprocal on \(K^\times \) show that inversion is continuous on the subspace \(A^\times \subseteq A\). Thus the inverse-graph map is continuous for that subspace topology; projection to the first coordinate is its continuous inverse. For the zero algebra the unit group is a singleton and the same topology agreement is immediate.
For a quadratic form \(Q\) on a finite-dimensional \(V\), apply this construction to the Clifford algebra \(A=\mathcal {C}\kern -2pt\ell (Q)\) and to \(\operatorname {End}_K(V)\). The orthogonal and special orthogonal groups inherit the matrix topology from \(\operatorname {End}_K(V)\). The actual vector-generated Lipschitz, Pin, and Spin carriers inherit the subspace topology from \(\mathcal {C}\kern -2pt\ell (Q)^\times \), equivalently from \(\mathcal {C}\kern -2pt\ell (Q)\). These topologies depend on the field topology and the algebraic carriers, without a choice of positive-definite norm or a replacement of the actual carriers by normalizer-defined groups. The star-unitary Pin convention and its even Spin restriction are used here; Remark [fcap-0028] compares the star and reverse norms.
The coordinate topology on \(W\) is also its module topology: it is
the finest topology making addition and scalar multiplication continuous.
The coordinate topology has these properties; for any other such topology,
the basis map \(K^d\to W\), a finite sum of scalar multiples of fixed basis
vectors, is continuous. This proves the claimed maximality.
Mathlib's moduleTopology defines that intrinsic topology, and
TauCeti's
CliffordAlgebra.instTopologicalSpaceCliffordAlgebra
uses it for \(\mathcal {C}\kern -2pt\ell (Q)\). The agreement with local coordinates follows from
the finite-dimensional argument above; the declaration itself is defined
over a general topological commutative ring.
Lemma. Closed local carriers and continuous Clifford actions [fcap-0045]AGENTDRAFTED
Definition [spin-000O]
Lemma. Closed local carriers and continuous Clifford actions [fcap-0045]AGENTDRAFTED
Let \(K\) be a local field of characteristic different from two in the sense of Definition [fcap-0044], and let \(Q\) be a nondegenerate quadratic form on a finite-dimensional \(K\)-space \(V\). Give all spaces and carriers the canonical topologies of that definition. Then \(O(Q)\) and \(SO(Q)\) are closed in \(\operatorname {End}_K(V)\), and the actual vector-generated \(\operatorname {Spin}(Q)\) is closed in \(A=\mathcal {C}\kern -2pt\ell (Q)\). These are locally compact Hausdorff topological groups. Their actions on \(V\) and the projection \(\rho :\operatorname {Spin}(Q)\to SO(Q)\) are continuous.
Assume first that \(n=\dim _K V>0\). Write \(\widehat v=\iota _Q(v)\), \(\alpha \) for the grading involution, and \(\operatorname {rev}\) for reversion. The vector-generated Lipschitz group has the following closed description inside \(A^\times \): \[\begin {gathered} \Gamma (Q)=\{x\in A^\times :\tau _x(V)\subseteq V\},\\ \tau _x(\widehat v)=\alpha (x)\widehat v x^{-1}. \end {gathered}\] Here and below \(V\) is identified with its embedded vector subspace. We verify this description so that the generated carrier is retained. If \(w=\alpha (x)\widehat v x^{-1}\in V\), applying \(\alpha \) also gives \(w=x\widehat v\alpha (x)^{-1}\). Multiplying the two expressions yields \(w^2=Q(v)1\). Thus \(\tau _x\) preserves \(Q\); nondegeneracy makes it injective, hence an isometry of \(V\). By Proposition [fcap-002D], choose a vector product \(y\in \Gamma (Q)\) with this action. For \(z=y^{-1}x\), \[\alpha (z)\widehat v=\widehat v z\qquad (v\in V).\] In an orthogonal basis \(e_1,\ldots ,e_n\), expand \(z\) in the Clifford monomials \(e_I\). For a fixed \(j\), the displayed equation is automatic on monomials with \(j\notin I\); on those with \(j\in I\), its two sides have opposite signs. The nonzero factors \(2Q(e_j)\) and linear independence force all their coefficients to vanish. Doing this for every \(j\) leaves only a scalar \(z=c1\), with \(c\ne 0\). For any \(Q(v)\ne 0\), \[c1=\widehat v\,\widehat {\left (\frac {c}{Q(v)}v\right )}.\] So \(c1\), and hence \(x\), belongs to \(\Gamma (Q)\). The reverse inclusion holds because each vector unit acts as a reflection. This also explains the general-field carrier argument behind the real case in Proposition [fcap-0037].
The actual Spin carrier is therefore \[\begin {gathered} \operatorname {Spin}(Q)=\{x\in A^{\mathrm {even}}:\\ \operatorname {rev}(x)x=1,\\ x\widehat v\operatorname {rev}(x)\in V\quad (v\in V)\}. \end {gathered}\] In finite dimension this left inverse is two-sided: \(L_{\operatorname {rev}(x)}L_x=1\) makes \(L_x\) invertible and gives \(x\operatorname {rev}(x)=1\). The preceding description now puts \(x\) in \(\Gamma (Q)\); evenness and reverse norm one are exactly the Spin conditions of Remark [fcap-0028]. Conversely every Spin element satisfies these equations. This is the norm-one convention: the star and reverse norms agree on even elements.
Every finite-dimensional linear subspace of \(A\) is closed: extend a basis and set the complementary coordinates equal to zero. Evenness and membership in \(V\) are consequently closed conditions. Reversion is linear, and multiplication is polynomial. It suffices to impose vector preservation on a basis of \(V\), so the displayed Spin carrier is a finite intersection of closed polynomial conditions in \(A\). The same argument, with continuous inversion on \(A^\times \), proves that \(\Gamma (Q)\) is closed in \(A^\times \).
Choose a basis of \(V\) and let \(G\) be the nonsingular Gram matrix of the half-polar form \(b_Q\) from Convention [fcap-0027]. Then \[\begin {aligned} O(Q)&=\{g:g^{\mathsf T}Gg=G\},\\ SO(Q)&=\{g\in O(Q):\det g=1\}. \end {aligned}\] The first equation already forces \(g\) invertible by taking determinants. These polynomial equations prove closedness in the whole matrix space. Matrix inversion, Clifford inversion and multiplication are continuous by Definition [fcap-0044]; their restrictions give the topological group operations. Finite-dimensional spaces over \(K\) are locally compact Hausdorff, so the closed carriers have those properties.
The joint action \((x,v)\mapsto \alpha (x)\widehat v x^{-1}\) is continuous by the same coordinate operations. Its values lie in the closed vector subspace, whose inverse identification with \(V\) is linear and continuous. Evaluating on a basis proves continuity of \(\tau :\Gamma (Q)\to O(Q)\) in matrix coordinates. Restricting to Spin removes \(\alpha \), and even determinant parity from Lemma [fcap-001A] places its image in \(SO(Q)\), proving continuity of \(\rho \). The joint matrix actions of \(O(Q)\) and \(SO(Q)\) are polynomial as well.
If \(V=0\), its only vector has zero quadratic value. There are no invertible vector generators, so \(\Gamma (Q)=\operatorname {Spin}(Q)=\{1\}\); both orthogonal groups are also trivial. All conclusions follow for these one-point carriers. The positive-dimensional normalizer description must not be used here: every Clifford unit preserves the zero vector space.
TauCeti proves closedness and local compactness for the actual carrier
in CliffordAlgebra.isClosed_spinGroup and
CliffordAlgebra.locallyCompactSpace_spinGroup.
The continuous projection is
TauCeti.CliffordAlgebra.continuous_spinToSpecialOrthogonal.
These declarations use canonical module and subgroup topologies; the first
two allow Hausdorff topological fields, with local compactness added for
the second. The projection itself needs neither nondegeneracy nor local
compactness. The argument above supplies their coordinate specialization.
Proposition. The open Clifford quotient and locally constant spinor norms [fcap-0046]AGENTDRAFTED
Proposition. The open Clifford quotient and locally constant spinor norms [fcap-0046]AGENTDRAFTED
Let \(K\), \(V\), \(Q\) and their topologies be as in Lemma [fcap-0045]. The continuous surjection \(\tau :\Gamma (Q)\to O(Q)\) is open and is a quotient map. Give \(\mathcal S_K=K^{\times }/(K^{\times })^2\) its quotient topology. It is discrete, and the two spinor norms of Proposition [fcap-002D], \[\begin {aligned} \nu _Q^O &: O(Q)\longrightarrow \mathcal S_K,\\ \nu _Q &: SO(Q)\longrightarrow \mathcal S_K, \end {aligned}\] are continuous and locally constant. In particular, \(\rho (\operatorname {Spin}(Q))=\ker \nu _Q\) is an open subgroup of \(SO(Q)\). This says that sufficiently small changes of an isometry preserve its square-class obstruction to a Spin lift.
Proof.
Proof.
First suppose \(\dim _K V>0\). Local fields are locally compact and \(\sigma \)-compact, meaning a countable union of compact subsets. For a nonarchimedean local field, its valuation ring is compact: completeness and the finite residue quotients make it a complete totally bounded metric space. Its scalar dilates exhaust \(K\); ordinary closed balls give the analogous exhaustion for \(\mathbb R\) and \(\mathbb C\). Finite products give compact exhaustions of \(A=\mathcal {C}\kern -2pt\ell (Q)\) and \(A^2\).
By Definition [fcap-0044], the units identify homeomorphically with the closed inverse graph \(\{(x,y):xy=yx=1\}\subseteq A^2\). Hence \(A^\times \) is locally compact and \(\sigma \)-compact. The closedness of \(\Gamma (Q)\) in Lemma [fcap-0045] gives the same properties to \(\Gamma (Q)\). Its vector action is continuous there and onto by Proposition [fcap-002D]; the target \(O(Q)\) is locally compact Hausdorff.
Here is the open-map argument. Given an open identity neighborhood
\(U\subseteq \Gamma (Q)\), choose an open identity neighborhood \(W\)
with compact closure and
\(\overline W\,\overline W^{-1}\subseteq U\). Such \(W\) exists by
continuity of multiplication and inversion and local compactness.
A compact exhaustion and finite subcovers of its terms give a countable
cover \(\Gamma (Q)=\bigcup _j g_jW\). Thus
\[O(Q)=\bigcup _j\tau (g_j)\tau (\overline W).\]
Each set in this union is closed, because \(\tau (\overline W)\) is
compact and the target is Hausdorff. The Baire theorem for locally
compact Hausdorff spaces implies that \(\tau (\overline W)\) has nonempty
interior. If \(D\) is a nonempty open subset of this image and \(d\in D\),
then \(Dd^{-1}\) is an open identity neighborhood contained in
\[\tau (\overline W)\tau (\overline W)^{-1}\subseteq \tau (U).\]
Translating this conclusion around every point of any open subset of
\(\Gamma (Q)\) proves that \(\tau \) is open. A continuous open surjection
is a quotient map: a subset of the target whose inverse image is open
is the open image of that inverse image. This is the argument underlying
Mathlib's MonoidHom.isOpenMap_of_sigmaCompact.
The reverse norm \(N_{\mathrm {rev}}:\Gamma (Q)\to K^\times \) is continuous. Indeed, Proposition [fcap-002D] identifies \(\operatorname {rev}(x)x\) with the scalar \(N_{\mathrm {rev}}(x)\); extracting its scalar coefficient is a linear map on \(A\). Its values are nonzero, and \(K^\times \) has the subspace topology from \(K\) by Definition [fcap-0044].
The square subgroup is open in \(K^\times \). Over \(\mathbb R\) it is the positive half-line, and over \(\mathbb C\) it is all of \(K^\times \). For a complete discretely valued field of characteristic different from two, let \(\mathcal O_K\) be its valuation ring and \(\mathfrak m_K\) its maximal ideal. The local square theorem gives \[1+4\mathfrak m_K\subseteq (K^\times )^2.\] This is [lam2005quadratic, VI.2, Theorem 2.19 and Corollary 2.20, p. 161]; its complete discrete valuation hypotheses apply also in residue characteristic two. Since \(4\ne 0\), multiplication by \(4\) is a homeomorphism, so the left side is an open identity neighborhood. Translating it by squares proves that the subgroup is open. Every square coset is therefore open, which makes its quotient \(\mathcal S_K\) discrete.
Let \(q:K^\times \to \mathcal S_K\) be the quotient map. The norm identity in Proposition [fcap-002D] is \[\nu _Q^O\circ \tau =q\circ N_{\mathrm {rev}}.\] The right side is continuous. The established quotient property of \(\tau \) therefore proves continuity of \(\nu _Q^O\); restricting to the subgroup \(SO(Q)\) proves continuity of \(\nu _Q\). A continuous map to a discrete space is locally constant. More explicitly, \[\ker \nu _Q^O=\tau \bigl (N_{\mathrm {rev}}^{-1}((K^\times )^2)\bigr )\] is open, since both the preimage and \(\tau \) are open. Its intersection with \(SO(Q)\) is \(\ker \nu _Q\), identified with the Spin image by Theorem [fcap-0023]. In dimension zero all domain groups are trivial by Lemma [fcap-0045]; the same square-class topology and conclusions apply.
TauCeti's CliffordAlgebra.isOpenMap_lipschitzToOrthogonal
uses a Hausdorff, locally compact, \(\sigma \)-compact topological field.
Its CliffordAlgebra.continuous_cliffordNorm uses a
complete nontrivially normed field. Finally,
CliffordAlgebra.continuous_orthogonalSpinorNorm,
CliffordAlgebra.continuous_spinorNorm and
CliffordAlgebra.isOpen_range_spinToSpecialOrthogonal
assume a locally compact nontrivially normed field and explicitly require
open squares. Each declaration assumes finite dimension and invertible
two, with nondegeneracy for the action and spinor-norm conclusions.
The local fields here satisfy those hypotheses, and the cited local
square theorem discharges the extra open-squares condition.
Theorem. Proper Spin projections and anisotropic compactness [fcap-0047]AGENTDRAFTED
Theorem. Proper Spin projections and anisotropic compactness [fcap-0047]AGENTDRAFTED
Let \(K\) be a local field of characteristic different from two as in Definition [fcap-0044], and let \(Q\) be a nondegenerate quadratic form on a finite-dimensional \(K\)-space \(V\). Use the canonical topologies of Definition [fcap-0044]. A continuous map is called proper here if the inverse image of every compact set is compact. The form \(Q\) is anisotropic if \(Q(v)=0\) implies \(v=0\); otherwise it is isotropic. This includes the zero-dimensional form as anisotropic, as in [lam2005quadratic, I.3, Definition 3.1, p. 9].
The Spin projection \(\rho :\operatorname {Spin}(Q)\to SO(Q)\) is proper, and \[\begin {gathered} \operatorname {Spin}(Q)\text { is compact}\\ \Longleftrightarrow \quad Q\text { is anisotropic}. \end {gathered}\] Anisotropy also makes \(O(Q)\) compact. The proofs below deduce these claims from the closed carriers and open Clifford quotient of Lemma [fcap-0045] and Proposition [fcap-0046], using the scalar-kernel and reverse-norm identities of Proposition [fcap-002D]. Thus compactness depends on the quadratic form, even when the projection has finite kernel.
Proof.
Proof.
If \(V=0\), the generated Spin carrier and both orthogonal groups are singletons by Lemma [fcap-0045]; all assertions follow. Suppose henceforth that \(\dim _K V>0\), and let \(C\subseteq O(Q)\) be compact. Write \(\tau :\Gamma (Q)\to O(Q)\) for the open surjection in Proposition [fcap-0046]. Choose a lift of each point of \(C\), and an open neighborhood of that lift with compact closure in the locally compact group \(\Gamma (Q)\). Their open images cover \(C\). A finite subcover therefore supplies a compact set \(L\subseteq \Gamma (Q)\) such that \(C\subseteq \tau (L)\). If \(C\) is empty, its preimage is already compact.
Let \(x\in \operatorname {Spin}(Q)\) have action in \(C\). Choose \(y\in L\) with \(\tau (y)=\rho (x)\), viewing \(SO(Q)\) inside \(O(Q)\). The scalar-kernel identity gives \(x=cy\) for some \(c\in K^\times \). The star-unitary Spin convention has reverse norm one on even elements by Remark [fcap-0028]. Hence the scalar-scaling identity of Proposition [fcap-002D] gives \[\begin {gathered} 1=c^2N_{\mathrm {rev}}(y),\\ c^2=N_{\mathrm {rev}}(y)^{-1}. \end {gathered}\] The inverse norm is continuous on \(L\) by Proposition [fcap-0046]. Its absolute value is bounded there, say by \(M\geq 1\), so \(|c|\leq \sqrt M\). Closed bounded scalar balls are compact over a local field: in the nonarchimedean case they are closed subsets of a scalar dilate of the compact valuation ring, and in the archimedean cases this is the usual closed-ball compactness. Write \(D=\{a\in K:|a|\leq \sqrt M\}\). Then the set \[DL=\{ay:a\in D,\ y\in L\}\] is compact in \(\mathcal {C}\kern -2pt\ell (Q)\), as a continuous image of a product of compact sets. The preimage of \(C\) in Spin is closed in the Clifford algebra: Spin is closed by Lemma [fcap-0045], \(C\) is closed in the Hausdorff group \(O(Q)\), and the projection is continuous. It is contained in the displayed compact set, so it is compact. A compact subset of \(SO(Q)\) is also compact in \(O(Q)\), proving properness of \(\rho \).
Suppose now that \(Q\) is anisotropic. Choose coordinates and put \(\|v\|=\max _i|v_i|\). The unit sphere \(\|v\|=1\) is a compact subset of the coordinate unit ball. On it the continuous function \(|Q|\) is positive, so has a positive minimum \(m\). For \(v\ne 0\), choose a coordinate \(a=v_j\) of maximal absolute value. Then \(\|a^{-1}v\|=1\), giving \[\begin {aligned} |Q(v)|&=|a|^2|Q(a^{-1}v)|\\ &\geq m\|v\|^2. \end {aligned}\] This also holds at zero. If \(g\in O(Q)\), its \(i\)-th column satisfies \(Q(ge_i)=Q(e_i)\), so the inequality bounds every column, uniformly in \(g\). The closed matrix carrier \(O(Q)\) from Lemma [fcap-0045] is consequently a closed subset of a compact finite product of scalar balls. Thus \(O(Q)\) is compact. Its inverse image is all of Spin, which is compact by the properness just proved.
Conversely, suppose \(Q\) is isotropic. Take \(u\ne 0\) with \(Q(u)=0\). Write \(B_Q\) for the unhalved polar form of Convention [fcap-0027]. Nondegeneracy supplies \(w\) with \(B_Q(u,w)=1\); set \(v=w-Q(w)u\). Then \(Q(v)=0\) and \(B_Q(u,v)=1\). Such \(u,v\) form a hyperbolic pair: their plane \(H=Ku+Kv\) has \(Q(au+bv)=ab\), and is nondegenerate, so \(V=H\perp H^\perp \). This is the hyperbolic plane of [lam2005quadratic, I.3, Theorems 3.2 and 3.4, pp. 9--10]; Lam's symmetric bilinear form is our half-polar form \(b_Q=B_Q/2\). It specializes to the real model in Definition [fcap-0012].
For \(t\in K^\times \), define \(h_t\) by \[\begin {gathered} h_tu=tu,\quad h_tv=t^{-1}v,\\ h_t|_{H^\perp }=\operatorname {id}. \end {gathered}\] It preserves \(Q\) and has determinant \(1\). Square classes have exponent two, so \(\nu _Q(h_t^2)=\nu _Q(h_t)^2=1\). The exact image statement Theorem [fcap-0023] therefore gives an actual Spin lift of each \(h_t^2\). Choose \(a\in K^\times \) with \(|a|>1\) and let \(t=a^r\), \(r=1,2,\ldots \). In a basis beginning with \(u,v\), the first diagonal entry of \(h_t^2\) is \(a^{2r}\), an unbounded scalar sequence. If Spin were compact, its continuous matrix image and every matrix coordinate would be compact, hence bounded. This contradiction proves noncompactness, including when \(H=V\) is a split binary plane.
TauCeti formalizes properness and the compactness criterion in
CliffordAlgebra.isProperMap_spinToSpecialOrthogonal
and CliffordAlgebra.isCompact_spinGroup_iff.
Their hypotheses are a weakly locally compact nontrivially normed field,
finite dimension, invertible two and nondegeneracy. The supporting
TauCeti.QuadraticMap.isCompact_orthogonalGroup
assumes anisotropy and finite dimension over the same kind of field,
without a separate nondegeneracy or characteristic condition. These
statements use the canonical module and subgroup topologies; on the
locally compact Hausdorff targets here, formal properness agrees with the
compact-preimage condition used above.
Example. Compact and split binary Spin groups over the 3-adic field [fcap-0048]AGENTDRAFTED
Example. Compact and split binary Spin groups over the 3-adic field [fcap-0048]AGENTDRAFTED
Over \(\mathbb Q_3\), with \(|3|_3=1/3\), consider \[\begin {aligned} Q_+(x,y)&=x^2+y^2,\\ Q_-(x,y)&=x^2-y^2. \end {aligned}\] Both forms are nondegenerate. In the canonical topologies, \(\operatorname {Spin}(Q_+)\) is compact and \(\operatorname {Spin}(Q_-)\) is not. This is a concrete application of Theorem [fcap-0047]. The local-field convention is Definition [fcap-0044]; the \(p\)-adic fields and their residue fields are included in [lam2005quadratic, VI.2, Definition 2.1 and discussion, pp. 151--152]. The calculations below establish the contrast directly.
If \(x^2+y^2=0\) and \(y=0\), then \(x=0\). If \(y\ne 0\), set
\(z=x/y\); then \(z^2=-1\). Its 3-adic valuation is zero, so \(z\) is a
unit in \(\mathbb Z_3\). Reduction modulo \(3\) would give a square
root of \(-1=2\) in \(\mathbb F_3\). But the two nonzero residues both
square to \(1\). Hence no such \(z\) exists, and \(Q_+\) is
anisotropic. Its Spin group is compact by
Theorem [fcap-0047]. The nonsquare input is also
Padic.not_isSquare_neg_one_of_mod_four_eq_three
at \(p=3\); TauCeti.anisotropic_binary_one_one_iff
identifies anisotropy of \(\langle 1,1\rangle \) with this nonsquare
condition over any field. These support the calculation, rather than
asserting a formalization of every displayed lift below.
For \(Q_-\), take \[\begin {gathered} u=(1,1),\\ v=(1/4,-1/4). \end {gathered}\] They satisfy \(Q_-(u)=Q_-(v)=0\) and \(B_{Q_-}(u,v)=1\), in the unhalved convention of Convention [fcap-0027]. They form a basis, and \(Q_-(au+bv)=ab\). Thus \(Q_-\) is a split hyperbolic plane, agreeing with [lam2005quadratic, I.3, Theorem 3.2, p. 9].
There is an explicit unbounded family in the Spin image. In the ordered basis \((u,v)\), let \(h_t=\operatorname {diag}(t,t^{-1})\), where \(t\in \mathbb Q_3^\times \). Write \(\widehat w=\iota _{Q_-}(w)\). Both \(tu+t^{-1}v\) and \(u+v\) have quadratic value one, so \[s_t=\widehat {(tu+t^{-1}v)}\,\widehat {(u+v)}\] lies in the actual vector-generated Spin group by Theorem [fcap-000C] and the reverse-norm convention in Remark [fcap-0028]. The reflection formula gives the following matrices in \((u,v)\): \[\begin {gathered} r_{tu+t^{-1}v}=\begin {pmatrix}0&-t^2\\-t^{-2}&0\end {pmatrix},\\ r_{u+v}=\begin {pmatrix}0&-1\\-1&0\end {pmatrix},\\ \rho (s_t)=r_{tu+t^{-1}v}r_{u+v},\\ \rho (s_t)=\begin {pmatrix}t^2&0\\0&t^{-2}\end {pmatrix}=h_t^2. \end {gathered}\] The product order is that of the two Clifford factors. Thus these are actual normalized lifts, not only abstract square-class witnesses.
Set \(t=3^{-r}\) for \(r\geq 1\). The first matrix entry has \(|t^2|_3=3^{2r}\), which is unbounded. The continuous image of a compact Spin group would have bounded matrix entries, proving that \(\operatorname {Spin}(Q_-)\) is not compact. In particular, binary noncompactness already follows from this torus family, without an orthogonal complement in which to construct transvections.
Proposition. Binary local spinor norms and the Spin index [fcap-0049]AGENTDRAFTED
Proposition. Binary local spinor norms and the Spin index [fcap-0049]AGENTDRAFTED
Let \(K\) be a nonarchimedean local field of characteristic different from two, as in Definition [fcap-0044], and let \(Q\) be a nondegenerate form on a finite-dimensional \(K\)-space. Use the reverse-norm convention of Proposition [fcap-002D]: \(\nu _Q^O\) is the spinor norm on \(O(Q)\), and \(\nu _Q\) is its restriction to \(SO(Q)\). Write \[\begin {gathered} S=K^{\times }/(K^{\times })^2,\\ I_Q=[SO(Q):\rho (\operatorname {Spin}(Q))]. \end {gathered}\] The kernel theorem Theorem [fcap-0023] gives \(I_Q=|\operatorname {im}\nu _Q|\). Thus the index of the Spin image in \(SO(Q)\) measures the size of the spinor-norm image, not its index in \(S\).
For the anisotropic form \(Q_+=\langle 1,1\rangle \) over \(\mathbb Q_3\) from Example [fcap-0048], both spinor-norm images are the square classes of norms from \(\mathbb Q_3(\sqrt {-1})\). They form the same index-two subgroup of \(S\). Since \(|S|=4\), the Spin index is \(I_{Q_+}=2\). The square-class count is [lam2005quadratic, VI.2, Theorem 2.22, p. 162]; the norm-image calculation follows from the general binary formulas below.
Suppose \(Q=\langle a,b\rangle \) is anisotropic, with \(a,b\in K^\times \), and put \(d=-b/a\). Then \(d\) is nonsquare and \(E=K(\sqrt d)\) is a quadratic field. Its field norm is \[N_{E/K}(x+y\sqrt d)=x^2-dy^2.\] The norm subgroup \(N=N_{E/K}(E^\times )\) contains \((K^\times )^2\), since \(N_{E/K}(c)=c^2\) for \(c\in K^\times \). Let \(H=N/(K^\times )^2\subseteq S\). Then \[\begin {gathered} \operatorname {im}\nu _Q=H,\\ \operatorname {im}\nu _Q^O=H\cup [a]H,\\ [S:H]=2,\\ I_Q=|H|=|S|/2. \end {gathered}\] In particular, \(\nu _Q^O\) is surjective exactly when \(a\notin N\). If \(a\in N\), both images are \(H\). If \(Q\) is split binary instead, both images are \(S\) and \(I_Q=|S|\).
The lower-dimensional boundary, with \(0\) denoting the form on the
zero space, is
\[\begin {array}{c|c|c}
Q&\operatorname {im}\nu _Q&\operatorname {im}\nu _Q^O\\ \hline
0&\{1\}&\{1\}\\
\langle a\rangle &\{1\}&\langle [a]\rangle
\end {array}\]
In both rows \(SO(Q)\) is trivial and \(I_Q=1\). In rank one,
\(O(Q)=\{1,-1\}\), and \(-1\) is reflection in the basis vector of
value \(a\); its norm is \([a]\). These statements agree with
CliffordAlgebra.spinorNorm_eq_one_of_finrank_le_one
and
CliffordAlgebra.orthogonalSpinorNorm_range_eq_zpowers_of_finrank_eq_one.
Proof.
Proof.
For the anisotropic binary form, the nonzero represented values are exactly \(aN\), because \(Q(x,y)=a(x^2-dy^2)\). Every isometry is a product of reflections by Theorem [fcap-000W], and determinant parity counts the factors by Lemma [fcap-001A]. Its spinor norm is the square class of the product of their quadratic values Proposition [fcap-002D]. Even products therefore have class in \(H\). Conversely, choose vectors with values \(a\) and \(an\) for any \(n\in N\). Their reflection product has class \([a^2n]=[n]\), so every class of \(H\) occurs on \(SO(Q)\). Multiplying by the reflection of value \(a\) gives the odd coset \([a]H\), proving the formula on \(O(Q)\). For a split binary form, the hyperbolic coordinate form \(xy\) represents every nonzero scalar; reflections of values \(1\) and \(c\) give any prescribed class \([c]\).
To obtain the index of \(N\), use the local Hilbert symbol \((u,v)_K\): it is \(1\) when the quaternion algebra \((u,v\mid K)\) is a matrix algebra, and \(-1\) otherwise. This is a symmetric bilinear pairing on \(S\), nondegenerate by [lam2005quadratic, VI.2, discussion on p. 159 and Theorem 2.16, p. 160]. The quaternion norm criterion [lam2005quadratic, III.2, Theorem 2.7(1), (8) and proof, pp. 58--59] says that \((n,d)_K=1\) exactly when \(n\in N\). Since \([d]\ne 1\), nondegeneracy makes \([n]\mapsto (n,d)_K\) onto \(\{1,-1\}\). Its kernel is \(H\), so \([S:H]=2\). The formula for \(I_Q\) follows from Theorem [fcap-0023]. For \(Q_+\), the first coefficient is \(1\in N\), so the two norm images coincide, as claimed.
The two binary image formulas are
CliffordAlgebra.range_spinorNorm_of_equivalent_binary
and
CliffordAlgebra.range_orthogonalSpinorNorm_of_equivalent_binary.
They use the parameter \(-ab=a^2d\), which gives the same quadratic
extension and norm subgroup. The local index and orthogonal
surjectivity criterion are
CliffordAlgebra.index_range_spinorNorm_of_finrank_eq_two_of_anisotropic
and
CliffordAlgebra.orthogonalSpinorNorm_surjective_iff_not_mem_quadraticNormSubgroup_of_anisotropic_binary.
The image formulas require finite dimension, nondegeneracy and invertible
two over a field; the index-two conclusion additionally uses the stated
local-field and anisotropy hypotheses.
Proposition. Higher-rank local spinor norms and square-class counts [fcap-004A]AGENTDRAFTED
Proposition. Higher-rank local spinor norms and square-class counts [fcap-004A]AGENTDRAFTED
Let \(K\) be a nonarchimedean local field of characteristic different from two, as in Definition [fcap-0044]. Let \(Q\) be nondegenerate on a finite-dimensional \(K\)-space \(V\) with \(\dim _K V\geq 3\). Use \(S=K^{\times }/(K^{\times })^2\), \(\nu _Q\), \(\nu _Q^O\) and \(I_Q\) as in Proposition [fcap-0049]. Every element of \(S\) is the spinor norm of a product of two reflections. Consequently, \[\begin {gathered} \operatorname {im}\nu _Q=\operatorname {im}\nu _Q^O=S,\\ I_Q=|S|. \end {gathered}\] This holds for anisotropic ternary and quaternary forms as well as isotropic forms. The input is the local isotropy theorem: every nondegenerate form of dimension at least five is isotropic [lam2005quadratic, VI.2, Theorem 2.12, pp. 158--159].
Proof.
Proof.
Fix \(c\in K^\times \). If \(Q\) is isotropic, a hyperbolic plane in \(V\) represents every scalar, so choose vectors of values \(1\) and \(c\); their reflection product has spinor norm \([c]\) by Proposition [fcap-002D]. To see the hyperbolic plane explicitly, take a nonzero isotropic \(u\). Nondegeneracy supplies \(w\) with \(B_Q(u,w)=1\), in the unhalved convention Convention [fcap-0027]. Then \(v=w-Q(w)u\) satisfies \(Q(v)=0\), \(B_Q(u,v)=1\), and \(Q(xu+yv)=xy\).
If \(Q\) is anisotropic, the nondegenerate form \[\begin {gathered} F(v,w)=Q(v)-cQ(w)\\ \text {on }V\oplus V \end {gathered}\] has dimension at least six. Restricting a diagonalization to five coordinates and applying the cited theorem gives a nonzero \((v,w)\) with \(Q(v)=cQ(w)\). Neither vector can vanish, since anisotropy would then force the other to vanish too. Set \(b=Q(v)\ne 0\); thus \(Q(w)=b/c\ne 0\). The two reflections give \[\begin {gathered} r_vr_w\in SO(Q),\\ \nu _Q(r_vr_w)=[b^2/c]=[c]. \end {gathered}\] The last equality uses \((b^2/c)/c=(b/c)^2\). This proves surjectivity on \(SO(Q)\), hence on \(O(Q)\). Finally, \(\rho (\operatorname {Spin}(Q))=\ker \nu _Q\) by Theorem [fcap-0023], so the first isomorphism theorem gives \(I_Q=|S|\).
Let \(k\) be the residue field, put \(q_0=|k|\), and normalize the additive valuation \(v_K:K^\times \to \mathbb Z\) to be surjective. Set \(e=v_K(2)\). The square-class count is \[|S|=4q_0^e\] by [lam2005quadratic, VI.2, Theorem 2.22, p. 162]. Here \(e=0\) in odd residue characteristic. Over \(\mathbb Q_2\), \(q_0=2\) and \(e=1\), so \(|S|=8\); see also [lam2005quadratic, VI.2, Corollary 2.24(1), p. 163]. Combining this count with Proposition [fcap-0049] gives the following Spin indices; the middle column means odd residue characteristic. \[\begin {array}{c|c|c} Q&\text {odd}&\mathbb Q_2\\ \hline \text {anis. binary}&2&4\\ \text {split binary}&4&8\\ \dim Q\geq 3&4&8 \end {array}\] The rank-zero and rank-one indices remain one. The characteristic restriction is on \(K\); residue characteristic two is included.
For a concrete dyadic contrast, \(x^2+y^2\) is anisotropic over \(\mathbb Q_2\): a nontrivial zero would make \(-1\) a square, but a 2-adic unit square is \(1\) modulo \(8\), whereas \(-1\) is \(7\) modulo \(8\) by the cited Corollary 2.24(1). Its Spin image therefore has index four, although its spinor-norm image has index two in \(S\). For the nondegenerate ternary form \(Q(x,y,z)=xy+z^2\), vectors \((1,c,0)\) and \((1,1,0)\) have values \(c\) and \(1\). Their reflection product realizes \([c]\) for every \(c\in \mathbb Q_2^\times \), and the Spin image has index eight.
The two-reflection assertion and its surjectivity consequence are
TauCeti.QuadraticMap.exists_reflectionPairSpecialOrthogonal_spinorNorm_eq
and
TauCeti.QuadraticMap.spinorNorm_surjective_of_three_le_finrank.
The count is TauCeti.natCard_squareClassGroup, and
the resulting Spin index is
TauCeti.QuadraticMap.index_range_spinToSpecialOrthogonal_of_three_le_finrank.
The reflection and index statements assume finite dimension,
nondegeneracy, invertible two and dimension at least three over a
nonarchimedean local field. The square-class count needs only that
field setting and \(2\ne 0\).
Example. A rational Spin obstruction vanishes over the 7-adic field [fcap-004B]AGENTDRAFTED
Example. A rational Spin obstruction vanishes over the 7-adic field [fcap-004B]AGENTDRAFTED
On the rational hyperbolic plane with basis \(u,v\), put \(q(au+bv)=ab\). Its unhalved polar form has matrix \(\left (\begin {smallmatrix}0&1\\1&0\end {smallmatrix}\right )\), so it is nondegenerate over both \(\mathbb {Q}\) and \(\mathbb {Q}_7\). We construct a rational special orthogonal transformation with no rational Spin lift, then exhibit its lift over \(\mathbb {Q}_7\). This specializes the scalar-extension criterion of Theorem [fcap-003N].
For \(c\ne 0\), write \(r_c=r_{u+cv}\). The reflection formula \(r_z(w)=w-B_q(w,z)z/q(z)\) gives, in the ordered basis \(u,v\), \[\begin {gathered} r_c=\begin {pmatrix}0&-c^{-1}\\-c&0\end {pmatrix},\\ g=r_2r_1=\begin {pmatrix}1/2&0\\0&2\end {pmatrix}. \end {gathered}\] Thus \(g\) preserves \(q\) and has determinant one. Since \(q(u+2v)=2\) and \(q(u+v)=1\), its spinor norm is \[\nu _q(g)=[2]_{\mathbb {Q}}\] by Proposition [fcap-002D]. This class is nontrivial: if \((a/b)^2=2\) for coprime integers \(a,b\) with \(b\ne 0\), then \(a^2=2b^2\) first makes \(a\) even and then makes \(b\) even, a contradiction. The image/kernel theorem Theorem [fcap-0023] therefore rules out a rational Spin lift of \(g\).
In \(\mathbb {Z}_7\), take \(f(T)=T^2-2\). We have
\(f(3)=7\) and \(f'(3)=6\), a unit. Hensel's lemma
[lam2005quadratic, VI.2, Theorem 2.18, p. 161] gives
\[\begin {gathered}
\alpha \in \mathbb {Z}_7,\qquad \alpha ^2=2,\\
\alpha \equiv 3\pmod {7}.
\end {gathered}\]
Indeed, in the theorem use the ideal \(7\mathbb {Z}_7\) and
\(e=f'(3)=6\): since \(e\) is a unit,
\(f(3)\in e^2(7\mathbb {Z}_7)\). In Mathlib's norm formulation
hensels_lemma, the same input satisfies
\(|f(3)|_7=1/7<1=|f'(3)|_7^2\).
In particular \(\alpha \ne 0\) and \([2]_{\mathbb {Q}_7}=1\).
Identify \(\mathbb {Q}_7\otimes _{\mathbb {Q}}V\) with the hyperbolic plane over \(\mathbb {Q}_7\), and denote the extended form and transformation by \(q_7,g_7\). Put \(\mathcal {S}_K=K^{\times }/(K^{\times })^2\). The square in Theorem [fcap-003N] becomes
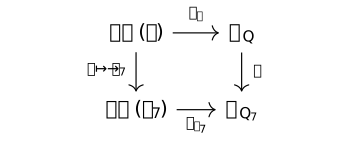
Suppress the Clifford inclusion symbols and use
\(u^2=v^2=0\), \(uv+vu=1\) in \(\mathcal {C}\kern -2pt\ell (q_7)\). Set
\(p=uv\) and \(x=(u+2v)(u+v)\). Then
\[\begin {gathered}
p^2=u(vu)v,\\
u(vu)v=u(1-uv)v=p,\\
x=uv+2vu=2-p,\\
\operatorname {rev}(x)=(u+v)(u+2v),\\
\operatorname {rev}(x)=1+p,\\
\operatorname {rev}(x)x=(1+p)(2-p),\\
(1+p)(2-p)=2.
\end {gathered}\]
Define
\[s=\frac {x}{\alpha }
=\left (\frac {u+2v}{\alpha }\right )(u+v).\]
Both displayed vector factors have quadratic value one. They are
Clifford units in the vector-generated Lipschitz carrier; their even
product has reverse norm \(2/\alpha ^2=1\). On an even element the
star and reverse norms agree by Remark [fcap-0028]. Thus \(s\) lies
in the actual \(\operatorname {Spin}(q_7)\), by the product-square construction
Theorem [fcap-000C]. Rescaling a nonisotropic vector leaves its
reflection unchanged, so the Spin action of \(s\) is
\[r_{(u+2v)/\alpha }\,r_{u+v}=r_2r_1=g_7.\]
This is the normalized-pair construction
CliffordAlgebra.spinReflectionPair and its action
CliffordAlgebra.spinToOrthogonal_spinReflectionPair:
the constructor assumes both quadratic values are one, and the
action identity also assumes that two is invertible. These declarations
certify the general pair construction; the arithmetic specialization
above is proved here.
The extension \(\mathbb {Q}\subset \mathbb {Q}_7\) has killed this particular square-class obstruction. The quadratic-extension example Proposition [fcap-003O] exhibits the same class becoming trivial over \(\mathbb {Q}(\sqrt {2})\) for a different quadratic form. Here the Hensel root and the displayed Clifford product give a lift at the single completion \(\mathbb {Q}_7\).
Definition. Compatible compact-open reference subgroups [fcap-004C]AGENTDRAFTED
Definition. Compatible compact-open reference subgroups [fcap-004C]AGENTDRAFTED
Let \(V\) be a finite-dimensional rational vector space and let \(Q\) be nondegenerate. For each rational prime \(p\), put \(V_p=\mathbb Q_p\otimes _{\mathbb Q}V\) and let \(Q_p\) be the extended form. Write \[\begin {gathered} O_p=O(Q_p),\\ SO_p=SO(Q_p),\\ \operatorname {Spin}_p=\operatorname {Spin}(Q_p),\\ \operatorname {Spin}_p\xrightarrow {\rho _p}SO_p\xrightarrow {i_p}O_p. \end {gathered}\] Here \(i_p\) is inclusion and \(\rho _p\) is the vector action. Spin is the actual vector-generated even norm-one carrier of Remark [fcap-0028], with the canonical local topology of Definition [fcap-0044]. The actions are continuous by Lemma [fcap-0045]. For a rational orthogonal or Spin point \(x\), write \(x_p\) for its scalar extension; the action compatibility is Theorem [fcap-003N].
A compatible compact-open reference tuple for \(Q\) consists of subgroups \[U_p^O\leq O_p,\qquad U_p^{\operatorname {Spin}}\leq \operatorname {Spin}_p\] at every prime, subject to the following requirements.
- Each subgroup is compact and open in its ambient local group.
- The reference groups respect the vector action: \[i_p\rho _p(U_p^{\operatorname {Spin}})\subseteq U_p^O.\]
- For each \(g\in O(Q)\), there is a finite set \(S_O(g)\) of primes such that \(g_p\in U_p^O\) whenever \(p\notin S_O(g)\).
- For each \(s\in \operatorname {Spin}(Q)\), there is a finite set \(S_{\operatorname {Spin}}(s)\) such that \(s_p\in U_p^{\operatorname {Spin}}\) whenever \(p\notin S_{\operatorname {Spin}}(s)\).
The exceptional sets may depend on the rational point. The special orthogonal reference subgroup is determined by these data: \[U_p^{SO}=i_p^{-1}(U_p^O).\] Thus an element of \(SO_p\) belongs to \(U_p^{SO}\) exactly when its underlying orthogonal transformation belongs to \(U_p^O\), and \(\rho _p\) restricts to \(U_p^{\operatorname {Spin}}\to U_p^{SO}\).
The subgroup \(U_p^{SO}\) is open by continuity of \(i_p\). It is compact because \(i_p\) is the closed embedding cut out by \(\det =1\), as in Lemma [fcap-0045]: its image inside \(U_p^O\) is closed in that compact set. If \(g\in SO(Q)\), determinant commutes with scalar extension, so the rational orthogonal membership condition gives \(g_p\in U_p^{SO}\) outside \(S_O(i(g))\), where \(i:SO(Q)\to O(Q)\) is inclusion. No further special orthogonal family or exceptional-set axiom is needed.
For an affine finite-type scheme over a discrete valuation ring,
its integral points are open and closed in its fraction-field points,
as in [conrad2011adelic, Example 2.3, p. 3]. The paired orthogonal
and Spin data above additionally impose compatibility and rational
membership. TauCeti packages those exact fields in
TauCeti.QuadraticMap.OrthogonalCompactOpens and
defines the derived subgroup in
TauCeti.QuadraticMap.OrthogonalCompactOpens.specialOrthogonal.
Its compactness is
TauCeti.QuadraticMap.OrthogonalCompactOpens.isCompact_specialOrthogonal.
The formal structure allows arbitrary rational quadratic forms; the
nondegenerate setting here supplies the existence construction in
Proposition [fcap-004D].
Proposition. A rational basis supplies compatible reference subgroups [fcap-004D]AGENTDRAFTED
Proposition. A rational basis supplies compatible reference subgroups [fcap-004D]AGENTDRAFTED
Let \(Q\) be a nondegenerate quadratic form on a finite-dimensional rational space \(V\), with basis \(b=(b_1,\ldots ,b_n)\). Use the local groups and maps of Definition [fcap-004C]. Let \(\mathbb Z_p\subseteq \mathbb Q_p\) be the ring of \(p\)-adic integers, and put \[\begin {gathered} b_{i,p}=1\otimes b_i,\\ L_p=\sum _{i=1}^n\mathbb Z_p b_{i,p},\\ H_p=\{g\in O_p:gL_p=L_p\}. \end {gathered}\] Then the choices \[\begin {gathered} U_p^O=H_p,\\ U_p^{\operatorname {Spin}}=(i_p\rho _p)^{-1}(H_p),\\ U_p^{SO}=i_p^{-1}(H_p) \end {gathered}\] form a compatible compact-open reference tuple. The Spin condition is integrality of its orthogonal action in both directions; it imposes no separate Clifford-coordinate integral model.
Proof.
Proof.
Suppose first that \(n>0\). In the basis \(b_p\), the condition \(gL_p=L_p\) means that both the matrix \(A\) of \(g\) and its inverse have entries in \(\mathbb Z_p\). Indeed, integral columns are exactly the condition \(gL_p\subseteq L_p\); the inverse condition gives the reverse inclusion. These conditions are closed under products and inverses, so \(H_p\) is a subgroup.
The ring \(\mathbb Z_p\) is open in \(\mathbb Q_p\). Every entry of \(A\) and \(A^{-1}\) varies continuously on \(O_p\) by Definition [fcap-0044]. Requiring their finitely many entries to lie in \(\mathbb Z_p\) is therefore an open condition, proving that \(H_p\) is open.
For compactness, retain both matrix coordinates. Let \(\mathcal C_p\subseteq M_n(\mathbb Z_p)^2\) be defined by \[\begin {gathered} AC=CA=I,\\ Q_p(Ax)=Q_p(x). \end {gathered}\] The second identity is required for every \(x\in V_p\). This is a finite collection of polynomial equations in the entries of \(A\): expand the two quadratic forms in the coordinates of \(x\) and equate their coefficients. The inverse equations are also polynomial. Thus \(\mathcal C_p\) is closed in \(M_n(\mathbb Z_p)^2\). Since \(\mathbb Z_p\) is compact, this finite product and its closed subset \(\mathcal C_p\) are compact. Projection \((A,C)\mapsto A\) identifies \(\mathcal C_p\) homeomorphically with \(H_p\); its inverse is \(A\mapsto (A,A^{-1})\). This is precisely the inverse-graph topology from Definition [fcap-0044]. Consequently \(H_p\) is compact. This matrix argument itself does not require nondegeneracy of the quadratic form.
The full action preimage \(U_p^{\operatorname {Spin}}\) is a subgroup and is open by continuity of \(i_p\rho _p\). Nondegeneracy persists over \(\mathbb Q_p\): a rational Gram determinant remains nonzero after the field embedding. The derived group \(U_p^{SO}\) is compact by the closed-inclusion argument in Definition [fcap-004C], so \[U_p^{\operatorname {Spin}}=\rho _p^{-1}(U_p^{SO})\] is compact by the properness theorem Theorem [fcap-0047]. This is the step that uses nondegeneracy. The full-preimage definition also gives \(i_p\rho _p(U_p^{\operatorname {Spin}})\subseteq H_p\) directly.
Fix one \(g\in O(Q)\). Its matrix and inverse matrix in the rational basis \(b\) contain finitely many rational entries. Let \(S_O(g)\) be the union of the prime divisors of their reduced denominators. It is finite. If \(p\notin S_O(g)\), each denominator is a unit of \(\mathbb Z_p\), so all entries of both localized matrices lie in \(\mathbb Z_p\). Hence \(g_p\in H_p\). There is no need to require the coefficients of \(Q\) to be integral in \(b\).
Now fix \(s\in \operatorname {Spin}(Q)\) and let \(g=i\rho (s)\in O(Q)\) be its rational orthogonal action. Scalar-extension naturality from Theorem [fcap-003N] gives \[i_p\rho _p(s_p)=g_p.\] The preceding argument therefore puts \(s_p\) in \(U_p^{\operatorname {Spin}}\) for every \(p\notin S_O(g)\). Taking \(S_{\operatorname {Spin}}(s)=S_O(i\rho (s))\) proves the remaining rational membership condition. The set is chosen separately for each \(s\); no uniform denominator bound on all rational Spin points is asserted.
If \(n=0\), the basis and all matrix-coordinate conditions are empty. Both orthogonal groups are trivial, and the actual generated Spin carrier is \(\{1\}\), by Lemma [fcap-0045]. Thus every displayed reference subgroup is the singleton group, compact and open, and all exceptional sets can be empty.
For example, in the hyperbolic plane \(Q(x,y)=xy\) with its standard rational basis, \(g=\operatorname {diag}(2,1/2)\) preserves \(Q\) and has determinant one. Both \(g\) and \(g^{-1}\) have integral entries at every prime except \(2\); thus \(S_O(g)=\{2\}\) works, and \(g_2\notin H_2\). This is the rational instance of the torus in Example [fcap-0048], and makes the point-dependent denominator condition explicit.
The matrix proof is a direct calculation using the local affine
topology of [conrad2011adelic, Proposition 2.1 and its proof, p. 2];
the compact Spin preimage is the deduction from Theorem [fcap-0047]
above. TauCeti's
TauCeti.QuadraticMap.isCompact_integralOrthogonalSubgroup
also permits degenerate local forms, whereas
TauCeti.CliffordAlgebra.isCompact_integralSpinSubgroup
requires nondegeneracy. The complete tuple is constructed in
TauCeti.QuadraticMap.OrthogonalCompactOpens.integral
for a nondegenerate rational quadratic form and a finite rational basis.
These references concern the chosen subgroups; they assert no
surjectivity of the restricted Spin action onto the orthogonal reference.
Proposition. Changing compact-open reference subgroups [fcap-004E]AGENTDRAFTED
Proposition. Changing compact-open reference subgroups [fcap-004E]AGENTDRAFTED
Let \(Q\) be nondegenerate on a finite-dimensional rational space \(V\). The compatible compact-open reference tuples constructed from any two rational bases in Proposition [fcap-004D] agree at all but finitely many primes, in each of their O, SO and Spin families.
There is also a finite shrinking operation. Given any compatible tuple \(U\), choose open subgroups \(W_p\leq O_p\) and a finite set \(F\) such that \(U_p^O\subseteq W_p\) for \(p\notin F\). Then \[\begin {gathered} \widetilde U_p^O=U_p^O\cap W_p,\\ \widetilde U_p^{\operatorname {Spin}} =U_p^{\operatorname {Spin}}\cap (i_p\rho _p)^{-1}(W_p),\\ \widetilde U_p^{SO}=i_p^{-1}(\widetilde U_p^O) \end {gathered}\] is another compatible tuple, contained in \(U\) at every prime and equal to it outside \(F\). In particular one may take \(W_p=O_p\) outside a chosen finite set. The maps \(i_p\) and \(\rho _p\) are those of Definition [fcap-004C].
Proof.
Proof.
For bases \(b\) and \(b'\), let \(C\) express the vectors of \(b'\) in the basis \(b\). Let \(F_b\) contain the denominator primes of every entry of both \(C\) and \(C^{-1}\). This is a finite set. Write \(L_p,L'_p\) for the respective \(\mathbb Z_p\)-spans of \(b_p,b'_p\). For \(p\notin F_b\), the entries of \(C\) belong to \(\mathbb Z_p\), so every vector of \(b'_p\) belongs to \(L_p\). Applying \(C^{-1}\) gives the reverse containment. Thus \(L'_p=L_p\). Their stabilizers in \(O_p\) are equal. Taking full preimages under \(i_p\rho _p\) and \(i_p\) gives equality of the Spin and SO references as well. No integrality condition on the coefficients of \(Q\) is needed.
For shrinking, an open subgroup of a topological group is closed: its complement is the union of its other open cosets. Hence \(U_p^O\cap W_p\) is open and is a closed subset of the compact group \(U_p^O\). The continuous action \(i_p\rho _p\) has an open and closed preimage of \(W_p\). Intersecting this preimage with the compact-open \(U_p^{\operatorname {Spin}}\) likewise gives an open compact subgroup. The action sends the Spin intersection into the orthogonal intersection. The derived SO group has the required properties by Definition [fcap-004C].
If \(p\notin F\), the orthogonal intersection equals \(U_p^O\). Compatibility of \(U\) gives \(i_p\rho _p(U_p^{\operatorname {Spin}})\subseteq U_p^O\subseteq W_p\), so the Spin intersection also equals \(U_p^{\operatorname {Spin}}\); the derived SO preimages are then equal. For a rational point \(x\), adjoining \(F\) to its original finite exceptional set proves eventual membership in the new references. The union is taken separately for each \(x\), as required. In dimension zero all groups are singletons and these statements retain their literal meanings.
For a concrete basis change in positive dimension, replace \(b_1\) by \(2b_1\) and leave the other basis vectors fixed. The two change matrices have diagonal entries \(2\) and \(1/2\), respectively, with all other diagonal entries \(1\). Thus \(F_b=\{2\}\) suffices. The two lattices agree at every odd prime, while at \(2\) the new lattice is strictly smaller. This does not assert that their orthogonal stabilizers must differ at \(2\).
These are deductions from the lattice construction in
Proposition [fcap-004D] and the continuous local action, using the
coordinate topology of [conrad2011adelic, Proposition 2.1, p. 2].
The basis comparison is formalized by
TauCeti.QuadraticMap.eventually_integralOrthogonalSubgroup_baseChange_eq,
which also permits degenerate forms. The compatible shrinking
construction is
TauCeti.QuadraticMap.OrthogonalCompactOpens.infOpenSubgroup.
Neither construction requires a lift of an arbitrary integral
orthogonal point to Spin.
Definition. Finite restricted products [fcap-004F]AGENTDRAFTED
Definition. Finite restricted products [fcap-004F]AGENTDRAFTED
Let \(G_p\) be a Hausdorff locally compact topological group at each rational prime, and choose a compact open subgroup \(U_p\leq G_p\). The restricted product relative to \(U=(U_p)\) is \[G_f(U)=\prod _p'(G_p,U_p).\] It consists of the tuples \((g_p)\in \prod _pG_p\) for which \(g_p\in U_p\) at all but finitely many primes. For a finite set \(S\) of primes its principal stage is \[G_S(U)=\prod _{p\in S}G_p\times \prod _{p\notin S}U_p,\] regarded as a subset of \(G_f(U)\) and given the product topology. The restricted-product topology declares \(A\subseteq G_f(U)\) open exactly when \(A\cap G_S(U)\) is open in every principal stage. Multiplication and inversion are coordinatewise. The product reference subgroup is \[K(U)=\prod _pU_p=G_{\varnothing }(U).\]
For example, take the hyperbolic plane \(Q(x,y)=xy\) and the references from its standard rational basis in Proposition [fcap-004D]. The tuple whose \(2\)-component is \(\operatorname {diag}(2,1/2)\) and whose other components are identities belongs to \(G_{\{2\}}(U)\) for \(G_p=O_p\), but not to \(K(U)\). The finite exceptional set permits a nonintegral component without discarding the restrictions at all other primes.
With this topology, \(G_f(U)\) is a Hausdorff locally compact topological group, each \(G_S(U)\) is an open subspace with precisely its product topology, and \(K(U)\) is compact and open. Every coordinate evaluation \((g_q)\mapsto g_p\) is continuous.
Proof.
Proof.
The identity belongs to every reference subgroup. The product of tuples with exceptional sets \(S\) and \(T\) has exceptional set contained in \(S\cup T\); inversion preserves a tuple's exceptional set. Thus the coordinate operations define a group on \(G_f(U)\), which is the union of its principal stages.
If \(S\subseteq T\), the inclusion \(G_S(U)\to G_T(U)\) replaces only the finitely many factors \(U_p\) for \(p\in T\setminus S\) by \(G_p\). Each inclusion \(U_p\hookrightarrow G_p\) is an open embedding, so the product inclusion is an open embedding. For arbitrary finite \(S,T\), \[G_S(U)\cap G_T(U)=G_{S\cap T}(U).\] This intersection is open in both stages with the same topology. If \(A\) is open in \(G_S(U)\), its intersection with \(G_T(U)\) is therefore open in \(G_T(U)\): first intersect with the open \(G_{S\cap T}(U)\), then use its open inclusion into \(G_T(U)\). Hence \(A\) is open in the union topology. Conversely, an open set of the union restricts to an open set in each stage by definition. This proves both the claimed stage topology and stage openness.
A coordinate evaluation is continuous on every stage, hence on the union by the definition of its topology. Two distinct tuples differ at some prime; disjoint neighborhoods in that Hausdorff factor pull back to disjoint neighborhoods of the tuples. Thus the union is Hausdorff. Multiplication restricts to a continuous map \[G_S(U)\times G_T(U)\longrightarrow G_{S\cup T}(U)\] by continuity in each factor of the product topology. These open products cover \(G_f(U)\times G_f(U)\), proving continuity of multiplication. Inversion is continuous on each open stage, hence on the union. Finally \(K(U)\) is compact by the product compactness theorem and open as the empty stage. Its translates are compact neighborhoods of every point, proving local compactness.
For a compatible compact-open reference tuple, apply this construction to the three local families to define the finite adelic orthogonal, special orthogonal and Spin groups: \[\begin {gathered} O_f(U)=\prod _p'(O_p,U_p^O),\\ SO_f(U)=\prod _p'(SO_p,U_p^{SO}),\\ \operatorname {Spin}_f(U)=\prod _p'(\operatorname {Spin}_p,U_p^{\operatorname {Spin}}). \end {gathered}\] The local topological groups are supplied by Lemma [fcap-0045]. The construction applies to the derived SO references as well as to the chosen O and Spin references. In dimension zero all three restricted products are singleton groups. Here the notation retains the chosen tuple; an arbitrary compatible tuple has not been identified with the integral points of an affine scheme.
Finite changes of references leave the ambient group and its topology unchanged. More precisely, suppose \(U'_p=U_p\) outside a finite set \(F\). A tuple restricted for one family is restricted for the other after adjoining \(F\) to its exceptions. The identity in every coordinate is thus a group isomorphism \(G_f(U)\to G_f(U')\). On a stage it factors as \[G_S(U)\longrightarrow G_{S\cup F}(U')\longrightarrow G_f(U').\] The first map is continuous: outside \(S\cup F\) the reference factors coincide, and at the finitely many remaining factors it is either the identity on \(G_p\) or the inclusion \(U_p\hookrightarrow G_p\). Stagewise continuity gives continuity on the union. Interchanging \(U\) and \(U'\) proves continuity of the inverse. Consequently the changes in Proposition [fcap-004E] identify the finite adelic topological groups by the coordinate identity.
This identity need not send \(K(U)\) onto \(K(U')\). If, for example, \(U'_{p_0}\) is a proper subgroup of \(U_{p_0}\), choose \(u\in U_{p_0}\setminus U'_{p_0}\). The tuple with component \(u\) at \(p_0\) and identities elsewhere belongs to \(K(U)\) but not to \(K(U')\). Thus the ambient topology and the chosen compact open subgroup are separate data. Continuity of all coordinate evaluations also shows that the restricted-product topology is at least as fine as the topology inherited from \(\prod _pG_p\).
The classical affine adelic construction uses finite stages and
open transition maps in [conrad2011adelic, Theorem 3.6, pp. 6-8];
compactness of integral points and the resulting locally compact
topology occur in [conrad2011adelic, Corollary 3.7 and Section 4 opening, p. 9].
The argument above proves the construction directly for the chosen
compact-open group references. Mathlib's
RestrictedProduct.isOpenEmbedding_inclusion_principal
and RestrictedProduct.locallyCompactSpace_of_group
support the stage and local compactness assertions. TauCeti's
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonal,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonal
and TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpin
define the three specializations. The coordinate identity and its
continuity are
TauCeti.restrictedProductCongr and
TauCeti.continuous_restrictedProductCongr.
Definition. Away restricted products and finite-prime splitting [fcap-004G]AGENTDRAFTED
Definition. Away restricted products and finite-prime splitting [fcap-004G]AGENTDRAFTED
Use the Hausdorff locally compact groups \(G_p\) and compact open references \(U_p\) of Definition [fcap-004F]. For any set \(R\) of rational primes, the away restricted product is \[G_f^R(U)=\prod _{p\notin R}'(G_p,U_p).\] Its tuples have only finitely many exceptions to \(g_p\in U_p\) among the primes outside \(R\). Its topology is defined by the same principal-stage construction, now indexed by finite sets \(T\subseteq \{p:p\notin R\}\): \[G_T^R(U)=\prod _{p\in T}G_p\times \prod _{p\notin R\cup T}U_p.\] The proof in Definition [fcap-004F] applies to this index set too. Thus \(G_f^R(U)\) is a Hausdorff locally compact topological group, and each displayed stage is open with its product topology.
Deleting the coordinates in \(R\) defines a continuous group homomorphism \[\begin {aligned} r_R:G_f(U)&\longrightarrow G_f^R(U),\\ (g_p)_p&\longmapsto (g_p)_{p\notin R}. \end {aligned}\] Indeed, a finite exceptional set \(S\) restricts to \(S\setminus R\), so the map is well defined. On the open stage \(G_S(U)\) it is the product-coordinate restriction \(G_S(U)\to G_{S\setminus R}^R(U)\), followed by the continuous stage inclusion. These restrictions are continuous, and the stages cover the source, proving continuity of \(r_R\). Coordinatewise operations prove the homomorphism assertion.
For \(R=\varnothing \), the away group and restriction are \(G_f(U)\) and its identity map. If \(R\) is the set of all primes, the complement is empty, so the away group is the one-point group and restriction is its unique incoming homomorphism. No finiteness of \(R\) is needed for the definition or for continuity.
If \(R\) is finite, separating its coordinates gives the finite-prime splitting, a topological group isomorphism \[\begin {aligned} d_R:G_f(U)&\longrightarrow \Bigl (\prod _{p\in R}G_p\Bigr )\times G_f^R(U),\\ (g_p)_p&\longmapsto \bigl ((g_p)_{p\in R},r_R(g)\bigr ). \end {aligned}\] The target carries the product topology. In particular the removed prime factors are unrestricted. For the hyperbolic-plane tuple in Definition [fcap-004F], choosing \(R=\{2\}\) gives \(d_R(g)=(\operatorname {diag}(2,1/2),1)\). Reinserting that component recovers the tuple, even though its \(2\)-component is outside \(U_2\).
Proof.
Proof.
The inverse of \(d_R\) reinserts the coordinates indexed by \(R\). If the away tuple has finite exceptional set \(T\), the reconstructed tuple has exceptional set contained in \(R\cup T\). This is finite, so the inverse is well defined. Coordinate restriction and reinsertion are mutually inverse homomorphisms. Continuity of \(d_R\) follows from the continuous coordinate evaluations of Definition [fcap-004F] and the continuous map \(r_R\).
For the inverse, the open subsets \[\Bigl (\prod _{p\in R}G_p\Bigr )\times G_T^R(U)\] cover the target as \(T\) ranges over the finite subsets of the complement. On each such subset reinsertion is the product rearrangement onto \(G_{R\cup T}(U)\), followed by its continuous inclusion into \(G_f(U)\). Hence the inverse is continuous on an open cover, and therefore continuous everywhere. This argument uses the established open stages and the ordinary product topology.
If \(R\) is infinite, the removed coordinates must retain their own restricted-product condition. An unrestricted family on \(R\) can have infinitely many components outside \(U_p\); reinserting it would not define a point of \(G_f(U)\). Thus the finite-prime formula does not extend by simply allowing infinite \(R\). The appropriate removed-coordinate factor is \(\prod _{p\in R}'(G_p,U_p)\). At the level of tuples this and the away factor split the finite exceptional set into two finite sets; conversely their union is finite. The resulting group isomorphism is also a homeomorphism: on each open product of two principal stages, reinsertion is a product rearrangement into the stage indexed by their union; restriction is continuous on every source stage. This also covers the empty and all-prime boundaries.
For a compatible compact-open reference tuple, the same construction defines \(O_f^R(U)\), \(SO_f^R(U)\) and \(\operatorname {Spin}_f^R(U)\) by taking the local families \(O_p\), \(SO_p\) and \(\operatorname {Spin}_p\) and their respective reference subgroups. The finite-prime splitting is a direct consequence of the stage topology; the classical affine adelic finite-stage decomposition is [conrad2011adelic, Theorem 3.6, equation (3.6.1), pp. 6-8].
TauCeti's TauCeti.RestrictedProductGroupAway
defines the arbitrary-set carrier, and
TauCeti.restrictAway with
TauCeti.continuous_restrictAway supplies restriction.
The finite-set splitting and its two continuity directions are
TauCeti.awayDecomposition,
TauCeti.continuous_awayDecomposition and
TauCeti.continuous_awayDecomposition_symm.
Its forward continuity does not need open references; inverse
continuity assumes openness on the away coordinates, which our
compact-open tuple supplies. The three specialized carriers are
TauCeti.QuadraticMap.OrthogonalCompactOpens.awayAdelicOrthogonal,
TauCeti.QuadraticMap.OrthogonalCompactOpens.awayAdelicSpecialOrthogonal
and TauCeti.QuadraticMap.OrthogonalCompactOpens.awayAdelicSpin.
Definition. Full adelic groups and the real factor [fcap-004H]AGENTDRAFTED
Definition. Full adelic groups and the real factor [fcap-004H]AGENTDRAFTED
Let \(Q\) be a nondegenerate quadratic form on a finite-dimensional rational vector space \(V\), and choose a compatible compact-open reference tuple. Extend scalars to \(V_\infty =\mathbb R\otimes _{\mathbb Q}V\), with quadratic form \(Q_\infty \). Write \(O_\infty \), \(SO_\infty \) and \(\operatorname {Spin}_\infty \) for its real groups with the canonical topologies of Definition [fcap-0044]. In particular \(\operatorname {Spin}_\infty \) uses the actual vector-generated, even, reverse-norm-one carrier of Lemma [fcap-0045].
The full adelic orthogonal, special orthogonal and Spin groups relative to the chosen references are \[\begin {aligned} O_{\mathbb A}(U)&=O_\infty \times O_f(U),\\ SO_{\mathbb A}(U)&=SO_\infty \times SO_f(U),\\ \operatorname {Spin}_{\mathbb A}(U)&=\operatorname {Spin}_\infty \times \operatorname {Spin}_f(U). \end {aligned}\] The finite factors are those of Definition [fcap-004F]. In each case take the ordinary product topology and coordinatewise group operations. There is no reference-subgroup condition at the real place: its factor is unrestricted. More generally write \(G_{\mathbb A}(U)=G_\infty \times G_f(U)\) for any of these three constructions. They are Hausdorff locally compact topological groups.
Indeed, Lemma [fcap-0045] gives those properties for the real factor, and Definition [fcap-004F] gives them for the finite factor. Multiplication and inversion are continuous in each component, hence in the product topology. Products of separating neighborhoods give the Hausdorff property. At each point choose compact neighborhoods in the two factors; their product is a compact neighborhood, proving local compactness. The finite-coordinate projection is the continuous group homomorphism \[\begin {aligned} \pi _f:G_{\mathbb A}(U)&\longrightarrow G_f(U),\\ (g_\infty ,g_f)&\longmapsto g_f. \end {aligned}\] Continuity is the defining property of the product topology, and the homomorphism identity follows from coordinatewise multiplication.
For example, take the hyperbolic plane \(Q(x,y)=xy\). For \(t>0\), the real matrix \(h_t=\operatorname {diag}(t,t^{-1})\) preserves \(Q\) and has determinant one. Thus \((h_t,1)\) is a point of \(SO_{\mathbb A}(U)\) for every \(t>0\), with identity at every finite prime. The nonidentity matrices \(h_t\) approach the identity as \(t\to 1\), exhibiting a nondiscrete real factor.
Let \(K(U)=\prod _pU_p\) be the compact open reference subgroup of the finite factor. The subgroup \(\{1\}\times K(U)\) of the full group is compact, but is not open when \(G_\infty \) is nondiscrete. Compactness follows from compactness of both factors. If the subgroup were open, its inverse image under the continuous map \(g\mapsto (g,1)\) would make \(\{1\}\) open in \(G_\infty \). Translations would then make every singleton open, contradicting nondiscreteness. Instead, for each open identity neighborhood \(W_\infty \subseteq G_\infty \), the set \(W_\infty \times K(U)\) is an open identity neighborhood in the full group. A compact real identity neighborhood \(C_\infty \) gives the compact identity neighborhood \(C_\infty \times K(U)\), without asserting that it is open. In dimension zero all three real and finite groups are singletons, so the nondiscreteness qualification is essential.
The unrestricted archimedean factors and the finite-place
conditions occur together in the classical affine adelic stage
formula of [conrad2011adelic, Theorem 3.6, equation (3.6.1), pp. 6-8].
Here the product construction is explicit for the chosen group
references; it makes no additional identification with integral
points of an affine scheme. TauCeti's
TauCeti.RestrictedProductGroupWithFactor
is the general carrier with an extra unrestricted factor.
The three specializations are
TauCeti.QuadraticMap.OrthogonalCompactOpens.fullAdelicOrthogonal,
TauCeti.QuadraticMap.OrthogonalCompactOpens.fullAdelicSpecialOrthogonal
and TauCeti.QuadraticMap.OrthogonalCompactOpens.fullAdelicSpin.
The corresponding continuous finite projections are
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_fullAdelicOrthogonalToFinite,
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_fullAdelicSpecialOrthogonalToFinite
and TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_fullAdelicSpinToFinite.
Example. A moving prime separates two topologies [fcap-004I]AGENTDRAFTED
Example. A moving prime separates two topologies [fcap-004I]AGENTDRAFTED
Use the hyperbolic plane \(Q(x,y)=xy\) and the integral orthogonal references of the example in Definition [fcap-004F]. Enumerate the rational primes without repetition as \(p_1,p_2,\ldots \). Define \(x_n\in O_f(U)\) by \[(x_n)_p=\begin {cases} \operatorname {diag}(p_n,p_n^{-1})&p=p_n,\\ 1&p\ne p_n. \end {cases}\] The exceptional diagonal matrix preserves \(xy\), and every other component is the identity. Thus \(x_n\) belongs to the principal stage \(O_{\{p_n\}}(U)\).
For each fixed prime \(p\), the coordinate \((x_n)_p\) is the identity for all but at most one \(n\). Hence \(x_n\to 1\) in the topology inherited from the unrestricted product \(\prod _pO_p\). Explicitly, a basic product neighborhood of the identity restricts only a finite set \(F\) of coordinates. Once the moving prime has passed every prime in \(F\), all those coordinates equal the identity, so the tuple belongs to that neighborhood.
In contrast, \(x_n\notin K(U)=\prod _pU_p^O\) for every \(n\): the entry \(p_n^{-1}\) is not in \(\mathbb Z_{p_n}\), so its matrix does not preserve the standard integral lattice. Since \(K(U)\) is an open identity neighborhood in the restricted-product topology, the sequence does not converge to the identity there. Coordinate continuity in Definition [fcap-004F] gives one topology inclusion; this sequence proves that the restricted-product topology is strictly finer in this example.
For the classical open-stage topology, see [conrad2011adelic, Section 4 opening, p. 9] and its finite-stage formula in Theorem 3.6. The calculation above isolates what that topology detects: the nonintegral coordinate keeps moving, although every fixed coordinate eventually becomes the identity.
Proposition. Adelic component maps and sign kernels [fcap-004J]AGENTDRAFTED
Definition [spin-000N]
Proposition. Adelic component maps and sign kernels [fcap-004J]AGENTDRAFTED
Let \(Q\) be a nondegenerate quadratic form on a rational vector space of finite dimension \(n\), with a compatible reference tuple \(U\) as in Definition [fcap-004C]. Let \(R\) be any set of primes. The local maps \(\rho _p:\operatorname {Spin}_p\to SO_p\) and \(i_p:SO_p\hookrightarrow O_p\) induce continuous group homomorphisms \[\begin {gathered} \operatorname {Spin}_f(U)\xrightarrow {\rho _f}SO_f(U)\xrightarrow {i_f}O_f(U),\\ \operatorname {Spin}_f^R(U)\xrightarrow {\rho ^R}SO_f^R(U)\xrightarrow {i^R}O_f^R(U),\\ \operatorname {Spin}_{\mathbb A}(U)\xrightarrow {\rho _{\mathbb A}} SO_{\mathbb A}(U)\xrightarrow {i_{\mathbb A}}O_{\mathbb A}(U). \end {gathered}\] The groups are defined in Definition [fcap-004F], Definition [fcap-004G] and Definition [fcap-004H]. Each \(i\) is injective, with image exactly the orthogonal tuples of determinant one at every retained place, including the real place for the full group. These maps commute with forgetting the real component and with deleting the primes in \(R\).
If \(n>0\), their Spin projection kernels are, as groups, \[\begin {aligned} \ker \rho _f&\cong \prod _p\{1,-1\},\\ \ker \rho ^R&\cong \prod _{p\notin R}\{1,-1\},\\ \ker \rho _{\mathbb A}&\cong \{1,-1\}\times \prod _p\{1,-1\}. \end {aligned}\] Every sign family occurs, with an independent real sign in the full case. These are algebraic identifications. If \(n=0\), all the groups and kernels above are singletons. If \(R\) contains every prime, the away groups and the empty sign product are singletons even when \(n>0\).
Proof.
Proof.
First consider continuous homomorphisms \(f_p:G_p\to H_p\) between the local groups of two restricted products, with \(f_p(U_p)\subseteq U'_p\) for every prime. If \(g\) has exceptional set \(S\), the tuple \((f_p(g_p))_p\) has exceptional set contained in \(S\). Thus coordinatewise application defines a homomorphism \(f:G_f(U)\to H_f(U')\). On each principal stage it factors through \[G_S(U)\longrightarrow H_S(U')\longrightarrow H_f(U').\] For \(p\in S\) use \(f_p\); outside \(S\) use its continuous restriction \(U_p\to U'_p\), with the subgroup topologies. The resulting product map is continuous. The second map is the continuous stage inclusion. Since the source stages form an open cover, \(f\) is continuous on the whole restricted product. The same proof on the index set \(\{p:p\notin R\}\) gives the arbitrary-away construction.
Compatibility of \(U\) says exactly that \(\rho _p\) preserves the Spin and SO references, while \(U_p^{SO}=i_p^{-1}(U_p^O)\) says that \(i_p\) preserves the SO and O references. Their local continuity is Lemma [fcap-0045], so the preceding argument gives the finite and away maps. For the full maps take the product with the actual continuous real maps \(\rho _\infty \) and \(i_\infty \) from that same local result. Products of continuous homomorphisms are continuous homomorphisms. In particular \[\rho _{\mathbb A}(s_\infty ,s_f) =(\rho _\infty (s_\infty ),\rho _f(s_f)).\]
Each local \(i_p\) is injective, so equality of images determines every coordinate and proves injectivity of \(i_f\) and \(i^R\). The real inclusion gives injectivity for \(i_{\mathbb A}\) too. Their images have determinant one at every place by definition. Conversely, let an orthogonal restricted tuple \(g\) have determinant one everywhere. Each \(g_p\) has a unique preimage \(h_p\in SO_p\). If \(S\) is an exceptional set for \(g\), then for \(p\notin S\), \[g_p\in U_p^O\quad \Longrightarrow \quad h_p\in i_p^{-1}(U_p^O)=U_p^{SO}.\] Thus \(h\) is restricted and maps to \(g\). Restricting the argument to \(p\notin R\) proves the away image criterion. In the full case, the real determinant-one condition supplies the unique real SO preimage as well. If no prime remains, the away criterion is vacuous and both sides are singleton groups.
Write \(\pi _f^{\operatorname {Spin}}\) and \(\pi _f^{SO}\) for the projections that forget the real component. The square
commutes because either path sends \((s_\infty ,(s_p)_p)\) to \((\rho _p(s_p))_p\). Replacing Spin and SO by SO and O gives the same square for \(i\), since both paths retain \((i_p(h_p))_p\). Deleting \(R\) commutes with each map for the same reason: both orders give \(\rho _p(s_p)\) or \(i_p(h_p)\) at every \(p\notin R\). This also proves the full-to-away identities by composition.
Suppose now that \(n>0\). The scalar-kernel theorem of Lemma [fcap-001C], applied over \(\mathbb Q_p\) and \(\mathbb R\), says that the local Spin projection kernel consists of the two scalar elements \(1,-1\). Scalar extension preserves dimension and nondegeneracy. An existing restricted Spin element therefore lies in the kernel exactly when each retained coordinate is a scalar sign; in the full case the real component must also be a sign.
It remains to show that arbitrary choices of signs really are restricted. Apply the rational membership axiom of Definition [fcap-004C] to the single rational Spin element \(-1\), which exists by Lemma [fcap-001C]. Scalar extension carries it to the local scalar \(-1\): the Clifford algebra map preserves \(1\) and negation, as in Theorem [fcap-003N]. There is consequently one finite set \(F\) such that \(-1\in U_p^{\operatorname {Spin}}\) for every \(p\notin F\). Also \(1\in U_p^{\operatorname {Spin}}\) at every prime. Every family \((\varepsilon _p)_p\in \prod _p\{1,-1\}\) is therefore restricted, with its exceptional set contained in this same \(F\), independently of the choices of signs. It lies in the projection kernel by the local scalar-kernel theorem.
Sending a sign family to its scalar tuple is injective because \(1\ne -1\) over these characteristic-zero fields, and is surjective onto the kernel by the existing-element criterion. It respects multiplication coordinatewise, proving the finite group isomorphism. Restricting the family and \(F\) to the complement of \(R\) gives the away isomorphism, including an empty complement. The real scalar sign is unrestricted and independent, giving the full product. Finally, if \(n=0\), Lemma [fcap-003H] identifies the actual generated Spin carrier with the identity subgroup; the orthogonal and special orthogonal groups are also trivial. Scalar extension and products preserve these singleton descriptions, so no extra scalar \(-1\) is introduced in that case.
For example, in positive dimension choose \(\varepsilon _2=-1\) and \(\varepsilon _p=1\) at every other prime. This is a kernel element distinct from both constant sign families. In the full group either real sign can accompany it. These projection kernels are different from the kernel of the spinor norm in Theorem [fcap-0023]: the present maps start in Spin and record its scalar ambiguity.
The classical finite-stage functoriality is described in [conrad2011adelic, Theorem 3.6 and the paragraph following its proof, pp. 6-8]. The real scalar-kernel prototype appears in [gallier2014clifford, Section 1.8, Proposition 1.21, pp. 39-40]. Gallier's Definition 1.6 uses norm \(\pm 1\); the local input here is the norm-one field theorem in Lemma [fcap-001C]. In particular this argument makes no claim that the Spin projections are surjective.
The generic construction and its continuity are supported by
TauCeti.restrictedProductMapOfForall and
TauCeti.continuous_restrictedProductMapOfForall.
The specialized continuity results are
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_finiteAdelicSpinToSpecialOrthogonal,
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_awayAdelicSpinToSpecialOrthogonal
and TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_fullAdelicSpinToSpecialOrthogonal.
For SO inclusion, the image criteria are
TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_range_finiteAdelicSpecialOrthogonalToOrthogonal_iff,
TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_range_awayAdelicSpecialOrthogonalToOrthogonal_iff
and TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_range_fullAdelicSpecialOrthogonalToOrthogonal_iff.
The displayed square is
TauCeti.QuadraticMap.OrthogonalCompactOpens.fullAdelicSpecialOrthogonalToFinite_comp_fullAdelicSpinToSpecialOrthogonal;
deletion compatibility is
TauCeti.QuadraticMap.OrthogonalCompactOpens.awayAdelicSpinToSpecialOrthogonal_comp_restrictAway.
The existing-element kernel criteria are
TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_ker_finiteAdelicSpinToSpecialOrthogonal_iff,
TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_ker_awayAdelicSpinToSpecialOrthogonal_iff
and TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_ker_fullAdelicSpinToSpecialOrthogonal_iff.
They support the coordinate criteria; the proof that every sign
family occurs is the additional rational \(-1\) argument above.
Definition. Rational diagonal subgroups [fcap-004K]AGENTDRAFTED
Definition. Rational diagonal subgroups [fcap-004K]AGENTDRAFTED
Let \(Q\) be a nondegenerate quadratic form on a finite-dimensional rational space \(V\), and let \(U\) be a compatible compact-open reference tuple. For \(G=O,SO,\operatorname {Spin}\), write \(G(Q)\) for the rational group, \(g_p\) for the scalar extension of \(g\in G(Q)\) to \(\mathbb Q_p\), and \(g_\infty \) for its extension to \(\mathbb R\). Spin always means the actual vector-generated even reverse-norm-one carrier. The rational diagonal homomorphisms are \[\begin {aligned} \delta _f^G:G(Q)&\longrightarrow G_f(U), &g&\longmapsto (g_p)_p,\\ \delta _{\mathbb A}^G:G(Q)&\longrightarrow G_{\mathbb A}(U), &g&\longmapsto (g_\infty ,(g_p)_p),\\ \delta _R^G:G(Q)&\longrightarrow G_f^R(U), &g&\longmapsto (g_p)_{p\notin R}, \end {aligned}\] where \(R\) is any set of rational primes. The targets are the finite, full and away groups of Definition [fcap-004F], Definition [fcap-004H] and Definition [fcap-004G]. Their images are the corresponding rational diagonal subgroups.
For O and Spin, the tuple axioms put each rational point in its reference subgroup at all but finitely many primes. For SO the same assertion follows from \(U_p^{SO}=i_p^{-1}(U_p^O)\), because determinant commutes with scalar extension. Thus the finite tuples are restricted. Deleting coordinates preserves this property, and the real factor imposes no reference condition. Scalar extension preserves products and identities, proving the homomorphism assertions.
For the hyperbolic form \(Q(x,y)=xy\), use the standard-basis references. The matrix \(g=\operatorname {diag}(2,1/2)\) gives a rational SO diagonal. Its finite components are integral except at \(2\), as computed in Proposition [fcap-004D]. The real component is the same rational matrix viewed over \(\mathbb R\). Deleting the \(2\)-coordinate puts its away image in the product of the remaining reference subgroups.
The finite and full diagonals are injective. The away diagonal is injective whenever at least one prime lies outside \(R\); in particular this holds for finite \(R\). If every prime is removed, its target is the singleton group, so the away map is injective only when \(G(Q)\) is itself trivial.
Proof.
Proof.
Scalar extension to any one retained completion detects a rational O or SO element: in a rational basis, equality of the extended matrices implies equality of every rational entry, because the field map is injective. For Spin, the Clifford scalar-extension isomorphism of Theorem [fcap-003V] identifies its underlying Clifford map with \[\mathcal {C}\kern -2pt\ell _{\mathbb Q}(Q)\longrightarrow L\otimes _{\mathbb Q}\mathcal {C}\kern -2pt\ell _{\mathbb Q}(Q), \qquad c\longmapsto 1\otimes c,\] where \(L=\mathbb R\) or \(\mathbb Q_p\). This map is injective: the extension of a rational vector-space basis is an \(L\)-basis, so zero extended coefficients force every original coefficient to vanish. Restricting to the actual Spin carrier preserves injectivity. Equality of diagonal tuples therefore implies equality at one completion and hence equality of their rational arguments. The finite product retains, for example, the prime \(2\); the full product also retains the real place. The away argument requires the stated nonempty complement. The empty product is a singleton.
The diagonals commute with the component maps \(\operatorname {Spin}\to SO\to O\) of Proposition [fcap-004J]. At each place this is the scalar-extension action identity of Theorem [fcap-003N]; for SO to O it is the equality of underlying matrices. The full-to-finite projection and coordinate restriction satisfy \[\pi _f\delta _{\mathbb A}^G=\delta _f^G, \qquad r_R\delta _f^G=\delta _R^G.\] These are equalities of homomorphisms, with no topology assigned to \(G(Q)\). If the rational domain is given the discrete topology, the maps are continuous; injectivity alone does not make a map a topological embedding.
The rational-point diagonal in classical affine full adelic
points is discussed in [conrad2011adelic, Example 2.3, p. 3].
Here restricted membership follows directly from the chosen tuple
axioms. TauCeti constructs the finite diagonals in
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonalDiagonal,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDiagonal
and TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpinDiagonal.
The full orthogonal construction is
TauCeti.QuadraticMap.OrthogonalCompactOpens.fullAdelicOrthogonalDiagonal;
the away injectivity condition is explicit in
TauCeti.QuadraticMap.OrthogonalCompactOpens.awayAdelicSpecialOrthogonalDiagonal_injective.
The Spin scalar-extension input is
CliffordAlgebra.spinGroupBaseChange_injective,
whose faithful, flat scalar-extension hypotheses hold for these fields.
The SO and Spin full and away maps use the same construction.
Proposition. Full rational diagonals are discrete under lattice containment [fcap-004L]AGENTDRAFTED
Proposition. Full rational diagonals are discrete under lattice containment [fcap-004L]AGENTDRAFTED
Let \(Q\) be nondegenerate on a finite-dimensional rational space \(V\), choose a compatible compact-open reference tuple \(U\), and fix a rational basis \(b\). Let \(L_p\) be its \(\mathbb Z_p\)-span and \(H_p=\{g\in O_p:gL_p=L_p\}\) as in Proposition [fcap-004D]. Assume the eventual lattice containment \[U_p^O\subseteq H_p\quad \text {for all but finitely many primes }p.\] Then each rational diagonal subgroup \[\delta _{\mathbb A}^O(O(Q)),\qquad \delta _{\mathbb A}^{SO}(SO(Q)),\qquad \delta _{\mathbb A}^{\operatorname {Spin}}(\operatorname {Spin}(Q))\] is discrete in its full adelic group. In particular this holds for the integral tuple of Proposition [fcap-004D], its rational-basis changes and its finite shrinkings from Proposition [fcap-004E].
Proof.
Proof.
Put \(W_p=U_p^O\cap H_p\). The groups \(W_p\) are open, since both factors are open by Definition [fcap-004C] and Proposition [fcap-004D]. Choose a finite set \(F\) outside which \(U_p^O\subseteq H_p\); then \(W_p=U_p^O\) for \(p\notin F\). Thus \[K_W=\prod _p W_p\subseteq O_f(U)\] is an open identity neighborhood. Indeed, inside the open principal stage \(O_F(U)\) it imposes an open condition on only the finitely many coordinates in \(F\), and leaves the other reference factors unchanged. This uses the stage topology of Definition [fcap-004F].
Let \(M_b(g_\infty )\) be the real matrix of \(g_\infty \in O_\infty \) in the extended basis, and put \[A=\left \{g_\infty \in O_\infty : \left |M_b(g_\infty )_{ij}-\delta _{ij}\right |<\tfrac 12 \text { for every }i,j\right \}.\] Here \(\delta _{ij}\) is the Kronecker delta. The finitely many matrix entries are continuous by Definition [fcap-0044], so \(A\) is open and contains the identity. Hence \(A\times K_W\) is an open identity neighborhood in \(O_{\mathbb A}(U)\).
Suppose a rational \(g\in O(Q)\) has diagonal in this neighborhood. Every \(g_p\) stabilizes \(L_p\); therefore each entry of its rational matrix \(M_b(g)\) belongs to \(\mathbb Z_p\) at every prime. A reduced fraction \(a/d\), with \(d>0\), has this property only if \(d=1\): a prime divisor \(p\) of \(d\) does not divide \(a\), giving negative \(p\)-adic valuation. Thus all the entries of \(M_b(g)\) are integers. Their real values differ from \(\delta _{ij}\) by less than \(1/2\); an integer with that property must equal \(\delta _{ij}\). Consequently \(g=1\). This isolates the identity in the orthogonal diagonal image. Translation by each diagonal element isolates every point of that image.
Pull the neighborhood back under the continuous inclusion \(SO_{\mathbb A}(U)\to O_{\mathbb A}(U)\) from Proposition [fcap-004J]. Naturality from Definition [fcap-004K] shows that its intersection with the rational SO image contains only the identity: the underlying rational orthogonal transformation is already the identity. This proves SO discreteness.
Pull this SO neighborhood back along the continuous map \(\rho _{\mathbb A}:\operatorname {Spin}_{\mathbb A}(U)\to SO_{\mathbb A}(U)\). A rational Spin point in this preimage has rational projection \(1\), by naturality and injectivity of the SO diagonal. If \(\dim V>0\), the field version of the scalar-kernel statement in Lemma [fcap-001C] gives precisely \(s=1\) or \(s=-1\). The real Spin group is Hausdorff, and the scalar elements \(1\) and \(-1\) are distinct there. Choose an open real identity neighborhood \(B_\infty \) excluding \(-1\). Intersect the preceding preimage with \(B_\infty \times \operatorname {Spin}_f(U)\). The intersection is open and its rational diagonal points consist of \(1\) alone. Translation proves Spin discreteness.
If \(\dim V=0\), the actual vector-generated Spin carrier is \(\{1\}\), as in Lemma [fcap-003H]; both orthogonal carriers are also singleton. The conclusion is immediate. In particular there is no extra scalar \(-1\) in this generated zero-dimensional carrier.
For the integral tuple, \(U_p^O=H_p\) at every prime. Finite shrinking only replaces reference subgroups by smaller ones, so it preserves containment. Changing rational basis changes \(H_p\) at only finitely many primes by Proposition [fcap-004E]. Adjoin these primes to the exceptional set to retain the hypothesis.
The separation has two independent parts: finite-place integrality forces rational matrix entries to be integers, and the real bound then forces the identity matrix. The finite projection discards the second condition. With the rational groups given the discrete topology, injectivity and the proved discrete images make these full diagonals topological embeddings; this argument asserts no such property for the finite diagonals.
[conrad2011adelic, Example 2.3, p. 3] proves discreteness
for rational points in classical affine full adelic points. The proof
above supplies the chosen-tuple version under its explicit containment
hypothesis, using Lemma [fcap-001C] for the Spin scalar kernel.
The exact O and SO criteria are
TauCeti.QuadraticMap.OrthogonalCompactOpens.discreteTopology_range_fullAdelicOrthogonalDiagonal_of_eventually_integral
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.discreteTopology_range_fullAdelicSpecialOrthogonalDiagonal_of_eventually_integral;
these two formal statements even allow degenerate forms.
TauCeti's
TauCeti.QuadraticMap.OrthogonalCompactOpens.discreteTopology_range_fullAdelicSpinDiagonal
proves the Spin conclusion for every nondegenerate compatible tuple,
using a separate eventual-containment theorem. The explicit containment
assumption is retained here to expose the neighborhood argument.
Proposition. Isotropic rational SO diagonals accumulate in the finite adeles [fcap-004M]
L∃∀NAGENTDRAFTED
Proposition. Isotropic rational SO diagonals accumulate in the finite adeles [fcap-004M]
L∃∀NAGENTDRAFTED
Let \(Q\) be nondegenerate on a rational vector space \(V\) of finite dimension \(d\geq 3\), and suppose that \(Q\) is isotropic. For every compatible compact-open reference tuple \(U\), the finite rational diagonal subgroup \(\delta _f^{SO}(SO(Q))\) is not discrete in \(SO_f(U)\). A sequence of nonidentity rational Eichler transvections converges to the identity while staying in one fixed principal stage.
Proof.
Proof.
Write \(B(x,y)=Q(x+y)-Q(x)-Q(y)\) for the unhalved polar form. Choose \(u\ne 0\) with \(Q(u)=0\). Nondegeneracy makes \(B(u,-)\) a nonzero functional, so its kernel \(u^\perp \) has dimension \(d-1\geq 2\). It contains the line \(\mathbb Q u\); choose \(w\in u^\perp \setminus \mathbb Q u\). The Eichler transvection of Proposition [fcap-002M] is \[T=E_{u,w}\in SO(Q),\qquad T^m=E_{u,mw} \quad (m\in \mathbb Z).\] The power formula follows from the additive composition law there.
Every nonzero integer power is nonidentity. Indeed, if \(E_{u,v}=1\) with \(v\in u^\perp \), its formula on \(x\in u^\perp \) reduces to \[E_{u,v}(x)-x=-B(x,v)u.\] Since \(u\ne 0\), this forces \(v\in (u^\perp )^\perp \). Nondegeneracy and finite dimension give \((u^\perp )^\perp =\mathbb Q u\): the left side has dimension one and contains \(u\). Taking \(v=mw\), with \(m\ne 0\), contradicts the choice of \(w\).
Apply the tuple's rational membership condition to the single element \(T\). There is a finite set of primes \(S\) such that \(T_p\in U_p^{SO}\) for every \(p\notin S\). Each reference is a subgroup, so every power \(T_p^{n!}\) belongs there too. Consequently all terms of the sequence \[g_n=\delta _f^{SO}(T^{n!})\quad (n\geq 1)\] belong to the same principal stage \[SO_S(U)=\prod _{p\in S}SO_p\times \prod _{p\notin S}U_p^{SO}.\] The identity also belongs to this stage. The exceptional set is independent of \(n\); separate exceptional sets for each term would not suffice for this convergence argument.
Fix a prime \(p\). With the valuation normalized by \(v_p(p)=1\), \[v_p(n!)\geq \lfloor n/p\rfloor \longrightarrow \infty , \qquad n!\longrightarrow 0\quad \text {in }\mathbb Q_p.\] Scalar extension of the formula for \(T\) gives \(T_p^{n!}=E_{u_p,n!w_p}\). In any fixed local basis, the entries of \(E_{u_p,tw_p}\) are polynomials in \(t\), with value the identity at \(t=0\). Its inverse is \(E_{u_p,-tw_p}\), whose entries have the same property. Hence \(T_p^{n!}\to 1\) in the canonical inverse-graph topology of Definition [fcap-0044]. For \(p\notin S\), the convergence also holds in the subgroup topology of \(U_p^{SO}\).
Coordinatewise convergence is convergence in the product topology of this one stage. Its inclusion into the restricted product is continuous by Definition [fcap-004F], so \(g_n\to 1\) in \(SO_f(U)\). The rational diagonal is injective by Definition [fcap-004K]; since \(n!\ne 0\), every \(g_n\ne 1\). If the diagonal image were discrete, an ambient neighborhood would meet it only at the identity, contrary to convergence of this sequence.
In the explicit matrix of Example [fcap-002N], take \(t=n!\). Its off-diagonal entries tend to zero at every finite prime, whereas the real entry \(t\) grows without bound. This exhibits what is lost on forgetting the real factor in Proposition [fcap-004L]. In dimension two, \(u^\perp =\mathbb Q u\), so the required parameter does not exist. No assertion about anisotropic forms or universal finite-diagonal nondiscreteness follows.
The transvection input is the general-field calculation in
Proposition [fcap-002M]; its totally singular special case is
[chevalley1954algebraic, III.1.7 and formula (1), pp. 73-74].
Chevalley's displayed formula assumes both parameters lie in a
totally singular subspace; the proof here uses the already established
arbitrary-\(Q(w)\) formula. The finite-stage topology is grounded in
[conrad2011adelic, Theorem 3.6, pp. 6-8].
The factorial argument above is a deduction from these inputs.
Its convergence statement is also
TauCeti.QuadraticMap.OrthogonalCompactOpens.tendsto_finiteAdelicSpecialOrthogonalDiagonal_transvection_factorial;
that statement needs the two polar identities but not the extra
nondegeneracy and dimension assumptions used to obtain a nontrivial
sequence.
Definition. The finite adelic spinor norm and its reference images [fcap-004N]AGENTDRAFTED
Definition. The finite adelic spinor norm and its reference images [fcap-004N]AGENTDRAFTED
Let \(Q\) be nondegenerate on a finite-dimensional rational space \(V\), and choose a compatible compact-open reference tuple \(U\). To collect the local spinor obstructions of one restricted SO tuple, the target must retain the images of its chosen reference subgroups. For each prime \(p\), put \[C_p=\mathbb Q_p^{\times }/(\mathbb Q_p^{\times })^2,\qquad \theta _p=\nu _{Q_p}:SO_p\longrightarrow C_p,\] using the reverse-norm spinor norm of Theorem [fcap-0023], with multiplicative notation. Give \(C_p\) its quotient topology. Define the spinor-norm reference image and the finite adelic square-class target by \[I_p=\theta _p(U_p^{SO}),\qquad C_f(U)=\prod _p'(C_p,I_p).\] The restricted-product notation and topology are those of Definition [fcap-004F]; explicitly \((c_p)_p\in C_f(U)\) means \(c_p\in I_p\) for all but finitely many \(p\).
Each \(C_p\) is discrete, including at \(p=2\). Indeed, Proposition [fcap-0046] proves that the square subgroup is open, using [lam2005quadratic, VI.2, Theorem 2.19 and Corollary 2.20, p. 161]. Every coset is then open, so every singleton in the quotient is open. The same local result proves that \(\theta _p\) is continuous. Since \(U_p^{SO}\) is compact, its image \(I_p\) is compact. A compact discrete set is finite: its open singleton cover has a finite subcover. Thus \(I_p\) is a finite open subgroup of \(C_p\), and the restricted product has the compact-open references required by Definition [fcap-004F].
The finite adelic spinor norm is the continuous homomorphism \[\begin {aligned} \Theta :SO_f(U)&\longrightarrow C_f(U),\\ (g_p)_p&\longmapsto (\theta _p(g_p))_p. \end {aligned}\] For if \(g_p\in U_p^{SO}\) outside a finite set \(S\), then \(\theta _p(g_p)\in I_p\) outside that same set. This proves restricted membership, and the local homomorphism laws give the global homomorphism law. Continuity is the component-map argument of Proposition [fcap-004J]: on each principal stage the map is the product of the continuous maps \(SO_p\to C_p\) for \(p\in S\) and their restrictions \(U_p^{SO}\to I_p\) elsewhere, followed by the continuous target-stage inclusion. The open stages cover the domain.
For example, a tuple equal to \(g\in U_\ell ^{SO}\) at one prime \(\ell \) and to the identity elsewhere maps to the tuple with \(\theta _\ell (g)\in I_\ell \) at \(\ell \) and identity elsewhere. It therefore lies in the target's product reference \(\prod _p I_p\). This describes the actual reference condition without replacing \(I_p\) by the square classes of local units or asserting that it is all of \(C_p\).
If \(\dim V=0\) or \(1\), every local \(SO_p\) is trivial. In dimension one a linear automorphism is scalar multiplication, and its determinant-one condition forces that scalar to be one; dimension zero has only the identity. Therefore every \(I_p=\{1\}\) and \(\Theta \) is the trivial homomorphism. The ambient square-class groups \(C_p\) need not be trivial. No surjectivity of \(\Theta \) is asserted in any dimension.
This construction combines the local square theorem with the
finite-stage functoriality described in
[conrad2011adelic, Theorem 3.6 and the following paragraph, pp. 6-8].
The actual-image choice is
TauCeti.QuadraticMap.OrthogonalCompactOpens.localSpinorNormImage,
and its openness is
TauCeti.QuadraticMap.OrthogonalCompactOpens.isOpen_localSpinorNormImage.
The target and continuous map are
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSquareClasses
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_adelicSpinorNorm.
These use the same chosen references and nondegeneracy assumption.
The low-rank image statement is
TauCeti.QuadraticMap.OrthogonalCompactOpens.localSpinorNormImage_eq_bot_of_finrank_le_one.
The compactness and finiteness of the images are the continuous-image
argument given above, not a separate square-class count.
Proposition. The adelic spinor kernel [fcap-004O]AGENTDRAFTED
Proposition. The adelic spinor kernel [fcap-004O]AGENTDRAFTED
Let \(Q\) be nondegenerate on a finite-dimensional rational space \(V\), and let \(U\) be a compatible compact-open reference tuple. Use the finite adelic spinor norm \(\Theta :SO_f(U)\to C_f(U)\), with its actual reference images \(I_p=\theta _p(U_p^{SO})\). Its kernel, called the adelic spinor kernel, is \[\ker \Theta =\{g\in SO_f(U):\theta _p(g_p)=1\text { for every prime }p\}.\] Give this subgroup the subspace topology from \(SO_f(U)\). The continuous Spin projection \(\rho _f\) of Proposition [fcap-004J] corestricts to a continuous homomorphism \[\bar \rho _f:\operatorname {Spin}_f(U)\longrightarrow \ker \Theta , \qquad (s_p)_p\longmapsto (\rho _p(s_p))_p.\] The formula retains exactly the same coordinates as \(\rho _f\).
Proof.
Proof.
The identity of the restricted product \(C_f(U)\) has identity at every prime. Thus \(\Theta (g)=1\) if and only if every \(\theta _p(g_p)=1\), proving the kernel description. For a restricted Spin element \(s\), the local image/kernel theorem Theorem [fcap-0023] gives \(\theta _p(\rho _p(s_p))=1\) at every prime. The already constructed \(\rho _f(s)\) is restricted, so it lies in \(\ker \Theta \). Corestriction preserves its homomorphism law.
Let \(j:\ker \Theta \hookrightarrow SO_f(U)\) be the inclusion. Every open subset of the kernel is of the form \(A\cap \ker \Theta \), for some open \(A\subseteq SO_f(U)\). Its preimage under \(\bar \rho _f\) is \(\rho _f^{-1}(A)\), which is open by continuity of \(\rho _f\). This proves continuity of the corestriction and the factorization \(j\bar \rho _f=\rho _f\).
The triangle records the factorization, with \(j\) the subgroup inclusion and no surjectivity assigned to either Spin arrow.
For a rational proper isometry \(g\in SO(V,Q)\), write \(\delta _f^{SO}(g)=(g_p)_p\) for its rational diagonal, and put \[j_p:\mathbb Q^{\times }/(\mathbb Q^{\times })^2\longrightarrow C_p, \qquad [a]_{\mathbb Q}\longmapsto [a]_{\mathbb Q_p}.\] Scalar-extension naturality from Theorem [fcap-003N] gives \[\bigl (\Theta (\delta _f^{SO}(g))\bigr )_p =j_p\bigl (\nu _Q(g)\bigr ).\] Consequently \(\nu _Q(g)=1\) implies \(\delta _f^{SO}(g)\in \ker \Theta \), since every homomorphism \(j_p\) sends the identity to the identity. No converse is asserted. The cited naturality proof covers positive dimension; in dimension zero the identity is the only proper isometry, so the same formula holds directly. If \(\dim V\leq 1\), all local SO groups, hence \(SO_f(U)\) and \(\ker \Theta \), are trivial, as in Definition [fcap-004N]. In dimension zero the actual Spin carrier is also trivial Lemma [fcap-003H]; no additional scalar sign is introduced.
For an arbitrary \(g\in \ker \Theta \), Theorem [fcap-0023] supplies a Spin lift of each local \(g_p\). Choosing these lifts separately does not prove that they belong to the chosen \(U_p^{\operatorname {Spin}}\) at all but finitely many primes. Thus the local lifting theorem alone does not establish surjectivity of \(\bar \rho _f\) for the chosen reference tuple.
The local reverse-norm argument is grounded in
[chevalley1954algebraic, II.3.5-6, pp. 52-53], with the
even-lift convention explained in Theorem [fcap-0023].
The kernel description and continuous corestriction above are
deductions from that local theorem and the restricted-product map.
Their precise formal counterparts are
TauCeti.QuadraticMap.OrthogonalCompactOpens.mem_adelicSpinorKernel_iff
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.continuous_finiteAdelicSpinToSpinorKernel.
The rational coordinate identity is
TauCeti.QuadraticMap.OrthogonalCompactOpens.adelicSpinorNorm_finiteAdelicSpecialOrthogonalDiagonal_apply;
its trivial-norm consequence is
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDiagonal_mem_adelicSpinorKernel.
These statements retain nondegeneracy and the same chosen references.
Definition. Finite adelic class sets [fcap-004P]AGENTDRAFTED
Definition. Finite adelic class sets [fcap-004P]AGENTDRAFTED
A restricted tuple of local transformations can be changed on the left by one rational transformation and on the right by a tuple in the chosen reference subgroups. The resulting equivalence classes depend on which of O, SO or Spin is used at both ends.
Let \(Q\) be nondegenerate on a finite-dimensional rational space \(V\), with a compatible compact-open reference tuple \(U\). Use the finite adelic groups of Definition [fcap-004F] and their rational diagonal subgroups. Define separately \[\begin {aligned} \Gamma _O&=\delta _f^O(O(V,Q)), & K_O&=\prod _p U_p^O,\\ \Gamma _{SO}&=\delta _f^{SO}(SO(V,Q)), & K_{SO}&=\prod _p U_p^{SO},\\ \Gamma _{\operatorname {Spin}}&=\delta _f^{\operatorname {Spin}}(\operatorname {Spin}(V,Q)), & K_{\operatorname {Spin}}&=\prod _p U_p^{\operatorname {Spin}}. \end {aligned}\] Each \(\Gamma _G\) is the actual image subgroup in \(G_f(U)\). Each \(K_G\) is its product reference subgroup, so it is compact and open by the restricted-product construction. The SO references are \(U_p^{SO}=i_p^{-1}(U_p^O)\); Spin uses its own chosen references and its actual generated carrier.
For each \(G\in \{O,SO,\operatorname {Spin}\}\), define a relation on \(G_f(U)\) by \[x\sim _G y\quad \Longleftrightarrow \quad \exists \gamma \in \Gamma _G\;\exists k\in K_G,\quad y=\gamma xk.\] The finite adelic class sets are the three quotient sets \[\begin {aligned} \mathcal C_O(U)&=\Gamma _O\backslash O_f(U)/K_O,\\ \mathcal C_{SO}(U)&=\Gamma _{SO}\backslash SO_f(U)/K_{SO},\\ \mathcal C_{\operatorname {Spin}}(U)&=\Gamma _{\operatorname {Spin}}\backslash \operatorname {Spin}_f(U)/K_{\operatorname {Spin}}. \end {aligned}\] Here \(\Gamma _G\backslash G_f(U)/K_G\) means the set of equivalence classes for \(\sim _G\), with no quotient topology assigned.
Proof.
Proof.
Reflexivity follows from \(x=1x1\). If \(y=\gamma xk\), then \(x=\gamma ^{-1}yk^{-1}\), and the inverses remain in their respective subgroups, proving symmetry. If also \(z=\eta y\ell \), where \(\eta \in \Gamma _G\) and \(\ell \in K_G\), then associativity gives \[z=\eta (\gamma xk)\ell =(\eta \gamma )x(k\ell ).\] The products \(\eta \gamma \in \Gamma _G\) and \(k\ell \in K_G\) give transitivity. Their order matters; neither subgroup is assumed commutative or normal. This proves the equivalence relation separately for all three groups.
The class of \(x\) is the double coset \(\Gamma _GxK_G\). In coordinates, equality of the classes of \(x\) and \(y\) means \[y_p=h_p x_p k_p\qquad \text {for every prime }p,\] for one rational \(h\in G(V,Q)\) and a tuple \((k_p)_p\in \prod _p U_p^G\). In particular, a tuple supported at one prime \(\ell \), with value \(u\in U_\ell ^G\) there, represents the identity class: it already lies in \(K_G\). The left changes must come from a single rational element; unrelated local left changes do not define this equivalence.
The actual products \(K_G\) are part of these definitions. Eventual equality of reference families identifies the ambient restricted products by Definition [fcap-004F], but it need not identify their product reference subgroups. The definition therefore does not supply a class-set bijection from eventual equality alone. In dimension zero all three class sets are singletons. These are quotient-set constructions, without a finiteness, measure or approximation assertion.
The finite-stage adelic construction and rational-point
diagonal have classical context in
[conrad2011adelic, Example 2.3, p. 3, and Theorem 3.6, pp. 6-8].
The quotient relation and its elementary verification above are
applied here to the explicit chosen subgroups, rather than
attributed to a class-number theorem. TauCeti's corresponding
definitions are
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonalDoubleCoset,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDoubleCoset
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpinDoubleCoset.
They use the rational diagonal ranges and the subgroups of tuples
lying in every reference, without assuming that those ranges
are discrete or that the double-coset sets are finite.
Proposition. Enlarging the right subgroup of a double coset [fcap-004Q]AGENTDRAFTED
Proposition. Enlarging the right subgroup of a double coset [fcap-004Q]AGENTDRAFTED
Let \(G\) be a group and let \(\Gamma ,K,K'\) be subgroups of \(G\), with \(K\subseteq K'\). Write \([x]_K\) for the double coset \(\Gamma xK\); throughout, \(\Gamma \) is fixed. There is a surjection \[\begin {aligned} p_{K,K'}:\Gamma \backslash G/K&\longrightarrow \Gamma \backslash G/K',\\ [x]_K&\longmapsto [x]_{K'}. \end {aligned}\] Thus allowing more right transformations can identify classes that were previously distinct.
Proof.
Proof.
If \([x]_K=[y]_K\), there are \(\gamma \in \Gamma \) and \(k\in K\) with \(y=\gamma xk\). The inclusion puts the same \(k\) in \(K'\), so the same witnesses give \([x]_{K'}=[y]_{K'}\). The assignment therefore does not depend on the representative. For any target class \(c\), choose a representative \(x\in G\) with \(c=[x]_{K'}\). Then \([x]_K\) is a source class and \(p_{K,K'}([x]_K)=c\), proving surjectivity.
Injectivity fails even for the group \(C_2=\{1,s\}\), where \(s^2=1\) and \(s\ne 1\). Take \(\Gamma =K=\{1\}\) and \(K'=C_2\). The source classes are exactly \(\{1\}\) and \(\{s\}\): with both witnesses equal to \(1\), two representatives are equivalent only when they are equal. The target has the single class \(C_2\), because \(\Gamma xK'=xC_2=C_2\) for each \(x\). Hence precisely two source classes map to one target class. This is a general-group counterexample, without an asserted adelic realization.
For the finite adelic class sets, fix a nondegenerate quadratic form \(Q\) on a finite-dimensional rational space \(V\) and one compatible compact-open reference tuple \(U\). Apply the proposition separately with \[(G,\Gamma ,K)= \bigl (H_f(U),\delta _f^H(H(V,Q)),K_H\bigr ), \qquad H\in \{O,SO,\operatorname {Spin}\}.\] Here the ambient restricted group is from Definition [fcap-004F], the rational image is from Definition [fcap-004K], and \(K_H\) is the actual product reference subgroup. Any subgroup \(K'_H\) of that same \(H_f(U)\) containing \(K_H\) gives the stated surjection. An enlargement of reference families does not by itself keep the ambient restricted product fixed; the proposition applies only after the ambient group and the rational diagonal have been identified.
The adelic objects have classical context in
[conrad2011adelic, Example 2.3, p. 3, and Theorem 3.6, pp. 6-8].
The quotient map and counterexample above are elementary group
arguments, not assertions quoted from that source. TauCeti's
DoubleCoset.quotientMapOfLERight_surjective
formalizes the general surjectivity statement. Its separate adelic
specializations are
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonalDoubleCosetMapOfLE_surjective,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDoubleCosetMapOfLE_surjective
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpinDoubleCosetMapOfLE_surjective.
No finiteness of these quotient sets is needed.
Proposition. Right translation and conjugate double cosets [fcap-004R]AGENTDRAFTED
Proposition. Right translation and conjugate double cosets [fcap-004R]AGENTDRAFTED
Let \(G\) be a group, let \(\Gamma ,K\leq G\), and fix \(a\in G\). Write \([x]_K\) for the double coset \(\Gamma xK\). Right translation induces a bijection \[\begin {aligned} T_a:\Gamma \backslash G/K&\longrightarrow \Gamma \backslash G/(a^{-1}Ka),\\ [x]_K&\longmapsto [xa]_{a^{-1}Ka}. \end {aligned}\] Its inverse sends \([z]_{a^{-1}Ka}\) to \([za^{-1}]_K\). The left subgroup stays \(\Gamma \); neither subgroup is assumed normal, and \(G\) need not be commutative.
Proof.
Proof.
The map \(c_a(k)=a^{-1}ka\) is a group automorphism: \(c_a(1)=1\) and \[(a^{-1}ka)(a^{-1}\ell a)=a^{-1}(k\ell )a,\] while its inverse is \(h\mapsto aha^{-1}\). Thus \(a^{-1}Ka=\{a^{-1}ka:k\in K\}\) is a subgroup: it contains \(1\), and the displayed product and \((a^{-1}ka)^{-1}=a^{-1}k^{-1}a\) keep products and inverses inside it.
Suppose \(y=\gamma xk\) with \(\gamma \in \Gamma \) and \(k\in K\). Associativity and cancellation give \[ya=\gamma (xa)(a^{-1}ka).\] Since \(a^{-1}ka\in a^{-1}Ka\), this proves that \(T_a\) is independent of the representative. For the proposed inverse, suppose \(w=\eta z h\), where \(\eta \in \Gamma \) and \(h\in a^{-1}Ka\). Choose \(k\in K\) with \(h=a^{-1}ka\). Then the inverse's witnesses are \(\eta \) and \(k\), since \[wa^{-1}=\eta z(a^{-1}ka)a^{-1} =\eta (za^{-1})k.\] The inverse assignment is therefore well defined. On a source representative its composite with \(T_a\) gives \((xa)a^{-1}=x\); on a target representative the other composite gives \((za^{-1})a=z\). Every quotient class has a representative, so both composites are the identity.
For the finite adelic class sets, fix a nondegenerate rational quadratic form and a compatible compact-open reference tuple \(U\). For each \(H\in \{O,SO,\operatorname {Spin}\}\), use the same ambient group \(H_f(U)\) of Definition [fcap-004F], its own rational diagonal subgroup \(\Gamma _H\), and its actual product subgroup \(K_H\). For \(a_H\in H_f(U)\), the bijection is \[\Gamma _H\backslash H_f(U)/K_H \longrightarrow \Gamma _H\backslash H_f(U)/(a_H^{-1}K_Ha_H).\] It changes the right subgroup inside this fixed group, without replacing the chosen O, SO or Spin rational image. It is a bijection of sets; no quotient topology, approximation or class-number assertion is involved.
The restricted groups and rational diagonals have adelic context in
[conrad2011adelic, Example 2.3, p. 3, and Theorem 3.6, pp. 6-8].
The conjugation calculation and inverse above are direct group
arguments, not statements attributed to that passage. TauCeti's
DoubleCoset.quotientConjRight
is the general equivalence with this orientation. The three
adelic specializations are
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonalDoubleCosetConj,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDoubleCosetConj
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpinDoubleCosetConj.
In their targets, the inverse conjugation automorphism sends
\(k\) to \(a_H^{-1}ka_H\), as in the displayed proof.
Proposition. Transporting double cosets by a group isomorphism [fcap-004S]AGENTDRAFTED
Proposition. Transporting double cosets by a group isomorphism [fcap-004S]AGENTDRAFTED
Let \(G,G'\) be groups, let \(\Gamma ,K\leq G\) and \(\Gamma ',K'\leq G'\), and let \(e:G\to G'\) be a group isomorphism satisfying \(e(\Gamma )=\Gamma '\) and \(e(K)=K'\). Then the double cosets are related by a bijection \[\begin {aligned} \overline e:\Gamma \backslash G/K&\longrightarrow \Gamma '\backslash G'/K',\\ [x]&\longmapsto [e(x)]. \end {aligned}\] Its inverse sends \([y]\) to \([e^{-1}(y)]\). Both subgroup equalities concern their images in the specified ambient groups.
Proof.
Proof.
If \(y=\gamma xk\) with \(\gamma \in \Gamma \) and \(k\in K\), then \[e(y)=e(\gamma )e(x)e(k).\] The two image equalities put \(e(\gamma )\) in \(\Gamma '\) and \(e(k)\) in \(K'\), so the proposed map is independent of the representative. Conversely, suppose \(w=\gamma 'zk'\) with \(\gamma '\in \Gamma '\) and \(k'\in K'\). The same equalities give \(e^{-1}(\gamma ')\in \Gamma \) and \(e^{-1}(k')\in K\), and \[e^{-1}(w)=e^{-1}(\gamma ')e^{-1}(z)e^{-1}(k').\] Thus the inverse assignment is well defined. Applying the two assignments successively to any representative gives \(e^{-1}(e(x))=x\) or \(e(e^{-1}(z))=z\), respectively. Every class has a representative, so both composites are identities.
For the finite adelic class sets, let \(Q,Q'\) be nondegenerate forms on finite-dimensional rational spaces \(V,V'\), with compatible compact-open reference tuples \(U,U'\). Fix one \(H\in \{O,SO,\operatorname {Spin}\}\) and suppose that group isomorphisms \[\phi _p:H(Q_p)\longrightarrow H(Q'_p)\] satisfy \(\phi _p(U_p^H)=U_p^{\prime H}\) at every prime. They induce a group isomorphism \[e_H:H_f(U)\longrightarrow H_f(U'),\qquad (x_p)_p\longmapsto (\phi _p(x_p))_p.\] Indeed, membership in a reference subgroup is equivalent at each coordinate, so a tuple and its image have the same finite exceptional set. The coordinatewise inverse is defined for the same reason; multiplication and the inverse identities hold at every coordinate.
Write \(\Gamma _H(U)=\delta _f^H(H(V,Q))\) and \(\Gamma _H(U')=\delta _f^{\prime H}(H(V',Q'))\) for the actual rational diagonal images. Assume additionally \[e_H(\Gamma _H(U))=\Gamma _H(U').\] Everywhere reference preservation gives \(e_H(\prod _pU_p^H)=\prod _pU_p^{\prime H}\): inclusion follows coordinatewise, and the coordinatewise inverse proves the reverse inclusion. The proposition therefore gives \(\mathcal C_H(U)\simeq \mathcal C_H(U')\), with representatives sent by \((x_p)_p\mapsto (\phi _p(x_p))_p\). The rational-image condition is a separate hypothesis; local group isomorphisms alone do not assert it. For SO use the derived reference subgroups \(i_p^{-1}(U_p^O)\) and \((i'_p)^{-1}(U_p^{\prime O})\); for Spin use its own references and actual generated carrier. The argument applies separately to all three groups, without identifying their rational images.
The adelic objects have classical context in
[conrad2011adelic, Example 2.3, p. 3, and Theorem 3.6, pp. 6-8].
The transport and inverse above are direct group arguments, not
claims quoted from that passage. TauCeti's
DoubleCoset.quotientCongr formalizes the general
equivalence. Its three corresponding specializations are
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicOrthogonalDoubleCosetCongr,
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpecialOrthogonalDoubleCosetCongr
and
TauCeti.QuadraticMap.OrthogonalCompactOpens.finiteAdelicSpinDoubleCosetCongr.
These are equivalences of sets; no continuity of the local
isomorphisms or quotient topology is assumed.
Proposition. Finite changes of references and the product subgroup [fcap-004T]AGENTDRAFTED
Proposition. Finite changes of references and the product subgroup [fcap-004T]AGENTDRAFTED
Let \(G_p\) be groups indexed by rational primes, with subgroups \(U_p,U'_p\leq G_p\) equal outside a finite set \(F\). Write \(G_f(U)\) and \(G_f(U')\) for their restricted products, regarded here as groups of tuples, and \(K(U)=\prod _pU_p\), \(K(U')=\prod _pU'_p\) for their product reference subgroups. The coordinate identity gives a group isomorphism \(e:G_f(U)\to G_f(U')\), but \[e(K(U))=K(U')\quad \Longleftrightarrow \quad U_p=U'_p\ \text {for every prime }p.\]
Proof.
Proof.
If \(x_p\in U_p\) outside a finite set \(S\), then \(x_p\in U'_p\) outside \(S\cup F\). Interchanging the two families proves the converse. Thus the two groups have the same tuples and coordinate operations, giving the stated isomorphism.
Everywhere equality of references immediately gives equality of their products. For the converse, suppose \(e(K(U))=K(U')\). Fix a prime \(p\) and \(u\in U_p\). The tuple with component \(u\) at \(p\) and identity at every other prime belongs to \(K(U)\). Its image is the same tuple in \(K(U')\), so \(u\in U'_p\). This proves \(U_p\subseteq U'_p\). Interchange the products and repeat the argument to obtain \(U'_p\subseteq U_p\). Since \(p\) was arbitrary, all reference subgroups agree.
In particular, finite changes need not preserve even the number of double cosets. Take \(G_p=C_2=\{1,s\}\) at every prime, with \(s^2=1\ne s\), and take \(U_p=C_2\) for every \(p\). Change only \(U'_2=\{1\}\), keeping \(U'_p=C_2\) for \(p\ne 2\). Both restricted products are \(\prod _pC_2\): the changed condition can fail only at \(2\). With left subgroup \(\Gamma =\{1\}\), the quotient by \(K(U)=\prod _pC_2\) has one class. The quotient by \(K(U')\) has exactly two classes, distinguished by the \(2\)-coordinate. Indeed, right multiplication by \(K(U')\) preserves that coordinate; if \(x_2=y_2\), then \(x^{-1}y\in K(U')\) and \(y=x(x^{-1}y)\). Both coordinates \(1,s\) occur. This is a group-family example, without an asserted realization by adelic O, SO or Spin groups.
For two compatible tuples \(U,U'\) for the same rational quadratic form, fix \(H\in \{O,SO,\operatorname {Spin}\}\) and suppose their \(H\)-references agree outside a finite set. The coordinate identity \(e_H\) identifies the ambient groups \(H_f(U)\) and \(H_f(U')\) and carries their actual rational diagonal images onto each other: both scalar extensions of any rational \(h\) have the same coordinate \(h_p\) at every prime. Thus Proposition [fcap-004S] gives \[\Gamma _H(U)\backslash H_f(U)/K_H(U) \simeq \Gamma _H(U')\backslash H_f(U')/e_H(K_H(U)).\] The right subgroup displayed in the target is the transported product, which equals \(K_H(U')\) exactly when all the \(H\)-references agree. Eventual equality alone does not supply the hypotheses for transport to \(\mathcal C_H(U')\) with its chosen right subgroup. This does not assert that different right subgroups always give nonisomorphic class sets. The O, derived SO and generated Spin cases each retain their own subgroups.
Finite-stage adelic constructions provide the background in
[conrad2011adelic, Theorem 3.6, pp. 6-8]; the product-subgroup
criterion and counterexample above are direct deductions.
TauCeti's
TauCeti.map_integralSubgroup_restrictedProductCongr_eq_iff
formalizes the criterion, and
TauCeti.doubleCosetCongr
transports double cosets to the image subgroups. Neither
statement replaces that image with a different product subgroup.
Remark. Algebraic extension versus topological cover [fcap-000Z]AGENTDRAFTED
Remark. Algebraic extension versus topological cover [fcap-000Z]AGENTDRAFTED
The extensions in Theorem [fcap-001D] and Theorem [fcap-001F] are exact sequences of abstract groups. They record a surjective homomorphism and its two-element kernel, but no topology. For the positive real form, the actual finite-dimensional carrier topology, compact double cover, and connectedness are established in Proposition [fcap-0039]; the stabilizer argument and the universal-cover boundary are established in Proposition [fcap-003A]. Those results do not extend the compact connectedness conclusion to arbitrary real signature.
Proposition. The compact real Spin projection is a two-sheeted cover [fcap-0039]AGENTDRAFTED
Proposition. The compact real Spin projection is a two-sheeted cover [fcap-0039]AGENTDRAFTED
For \(n\geq 0\), let \[Q_n^+(x)=\sum _{i=1}^n x_i^2\] on \(\mathbb R^n\), and give its actual vector-generated group \(\operatorname {Spin}(Q_n^+)\) the subspace topology from the finite-dimensional real Clifford algebra. This group is compact for every \(n\); it is path-connected for \(n\geq 2\). For \(n\geq 1\), the vector action is a two-sheeted covering \[\operatorname {Spin}(Q_n^+)\longrightarrow SO(n)\] with kernel \(\{1,-1\}\).
Here is the compactness mechanism. Cartan--Dieudonne writes every special orthogonal transformation as a bounded even word of reflections. Positive definiteness normalizes every reflecting vector to the unit sphere. An additional unit-vector pair corrects the possible scalar \(-1\), and pairs \((e,e)\) pad the lift to a fixed length. Clifford multiplication therefore gives a continuous surjection \[\bigl (S^{n-1}\times S^{n-1}\bigr )^{n+1} \longrightarrow \operatorname {Spin}(Q_n^+)\qquad (n\geq 1).\] For \(n=0\), the actual vector-generated carrier is the singleton group, hence compact. For \(n\geq 1\), the displayed source is compact, proving compactness. For \(n\geq 2\) it is also path-connected, proving path-connectedness of the target. The plane curve in Example [fcap-0038] independently joins \(1\) to \(-1\).
The vector action is a continuous surjection onto the Hausdorff group \(SO(n)\). Compactness makes it a quotient map. Its two-element kernel is discrete and acts freely, so the quotient-covering theorem makes the action a two-sheeted covering. The finite kernel alone would not prove either the quotient-map or covering assertion.
[gallier2014clifford, Section 1.8, pp. 38--40] gives the compact double cover for \(n\geq 1\) and path-connectedness for \(n\geq 2\), using generators with negative square in \(\operatorname {Cl}_{0,n}\). [lawson2016spin, I.2 and I.4, pp. 14, 19, 25] use the same compact sign through \(v^2=-q(v)\).
To compare their carrier with the positive-square model above, let \(e_i^2=1\) and \(f_i^2=-1\). The complex map \(e_i\mapsto i f_i\) restricts on real even PBW words to \[F(e_{i_1}\cdots e_{i_{2k}}) =(-1)^k f_{i_1}\cdots f_{i_{2k}}.\] The same formula is its inverse. It is a real linear homeomorphism, preserves multiplication and reversal, and carries an even product of real vectors to the corresponding even product up to a scalar \(-1\). That scalar belongs to both actual carriers, since \(e(-e)=-1\) and \(ff=-1\). Thus \(F\) and its inverse identify the actual Spin carriers. Complexifying the vector action and cancelling the common factor \(i\) shows that they also intertwine the actions on \(\mathbb R^n\). Gallier defines Spin through a normalizer condition; the carrier-completion argument in Proposition [fcap-0037], applied after this sign transfer, identifies that normalizer-defined group with the selected vector-generated carrier. This translates the source convention without identifying the two full real Clifford algebras.
TauCeti proves compactness for every \(n\), path-connectedness in
dimensions \(n+2\), and the quotient-covering and covering statements for
nonzero dimension:
CliffordAlgebra.instCompactSpaceRealCliffordSpinGroupZero,
CliffordAlgebra.pathConnectedSpace_realCliffordSpinGroupZero_add_two,
CliffordAlgebra.isQuotientCoveringMap_realCliffordSpinDoubleCoverZero_rightHom,
and
CliffordAlgebra.isCoveringMap_realCliffordSpinDoubleCoverZero_rightHom.
These exact results concern the positive form and the finite-dimensional
carrier topology; they do not assert simple connectedness.
Proposition. The compact Spin cover is universal from dimension three [fcap-003A]AGENTDRAFTED
Proposition. The compact Spin cover is universal from dimension three [fcap-003A]AGENTDRAFTED
For \(n\geq 3\), the covering in Proposition [fcap-0039] is the universal covering of \(SO(n)\). The proof uses the action on the unit sphere from Theorem [fcap-0024], together with the topology just supplied.
Fix a unit vector \(e\). Its stabilizer in \(\operatorname {Spin}(Q_n^+)\) is the preimage of \(SO(e^\perp )\). The Clifford map for the orthogonal inclusion \(e^\perp \hookrightarrow \mathbb R^n\) embeds \(\operatorname {Spin}(Q_{n-1}^+)\) into that preimage, maps onto \(SO(e^\perp )\), and has the same kernel \(\{1,-1\}\). Hence the embedded subgroup is exactly the stabilizer. It is closed. Using the concrete Lie group structure of Proposition [fcap-0037], the closed-subgroup bundle theorem gives \[\operatorname {Spin}(n-1)\longrightarrow \operatorname {Spin}(n)\longrightarrow S^{n-1}.\] This supplies the stabilizer step rather than inferring a fibration from transitivity alone.
One can see the local section directly in the positive-square
convention. For a unit vector \(x\ne -e\), put
\[u(x)=\frac {e+x}{\sqrt {Q_n^+(e+x)}},\qquad
s(x)=\iota (u(x))\iota (e).\]
Positive definiteness makes the denominator nonzero, and both vectors
have square one. Thus \(s(x)\) is even with reverse norm one. If
\(h=\iota (e+x)\), the Clifford relation gives
\[h\iota (e)h=\bigl (2+B_Q(e,x)\bigr )\iota (x)
=Q_n^+(e+x)\iota (x),\]
so \(s(x)\iota (e)s(x)^{-1}=\iota (x)\). The formula is continuous on
\(S^{n-1}\setminus \{-e\}\). In TauCeti \(e\) is the last coordinate
vector: TauCeti.realCliffordSpinLastLocalSection_apply
records the formula,
TauCeti.continuousOn_realCliffordSpinLastLocalSection
its continuity on that punctured sphere, and
TauCeti.realCliffordSpinLastLocalSection_action
its orbit identity. The definition assigns the identity at \(-e\); this
totalization is not a continuous section on the whole sphere.
With \(k=n-1\geq 1\),
CliffordAlgebra.realCliffordSpinContinuousMulEquivLastStabilizer
identifies \(\operatorname {Spin}(k)\) with the entire last-vector stabilizer in
\(\operatorname {Spin}(k+1)\), continuously and multiplicatively.
CliffordAlgebra.exists_realCliffordSpinOrbitTrivialization
then provides a bundle chart around every sphere point \(y\), with base
\(S^k\setminus \{-y\}\) and fiber \(\operatorname {Spin}(k)\); the resulting fiber-bundle
statement is
CliffordAlgebra.isFiberBundle_realCliffordSpinOrbitMap.
These are charts for the actual orbit map, with the same rank shift as
the displayed bundle.
For \(n=3\), Example [fcap-002H] gives the coordinate isomorphism with unit quaternions. Its displayed linear map and inverse restrict continuously to the unit three-sphere, so \(\operatorname {Spin}(3)\) is simply connected. For \(n\geq 4\), the homotopy exact sequence of the bundle and simple connectedness of \(S^{n-1}\) give a surjection \[\pi _1\operatorname {Spin}(n-1)\longrightarrow \pi _1\operatorname {Spin}(n).\] Induction therefore gives \(\pi _1\operatorname {Spin}(n)=0\) for every \(n\geq 3\). Together with path-connectedness and the two-sheeted covering, this makes \(\operatorname {Spin}(n)\to SO(n)\) the universal cover.
The formal base case uses
TauCeti.realSpinThreeContinuousMulEquivQuaternionUnitary,
the continuous multiplicative quaternion equivalence corresponding to
Example [fcap-002H]. The full conclusion
CliffordAlgebra.simplyConnectedSpace_realCliffordSpinGroupZero
establishes simple connectedness for every \(n\geq 3\). Its induction
uses the two antipodal bundle charts: their bases are contractible
punctured spheres, their fibers are simply connected by induction, and
their overlap is path-connected. Van Kampen then gives simple
connectedness of the total space. This implements the same geometric
induction through charts rather than the homotopy exact sequence used
above. The quaternion case starts the induction; \(\operatorname {Spin}(2)\) is not a
simply connected base case. Combining this conclusion with
Proposition [fcap-0039] yields the universal-cover assertion.
[gallier2014clifford, Section 1.8, pp. 40--42] gives this sphere--stabilizer induction. [meinrenken2013clifford, Section 1.6, Lemma 1.4, p. 13] independently checks the base topology using the parallel sphere fibration for \(SO(n)\). The explicit carrier/stabilizer comparison above is the convention bridge to the selected positive-square model.
The lower ranks remain separate: \[\begin {array}{c|c|c} n&\operatorname {Spin}(n)&\text {cover behavior}\\ \hline 0&\{1\}&\text {separate trivial carrier}\\ 1&\{1,-1\}&\text {two sheets over }SO(1),\ \text {not universal}\\ 2&S^1&\text {twofold circle cover of }SO(2),\ \pi _1\ne 0. \end {array}\] The rank-two identification follows from \(a+b e_1e_2\) with \(a=\cos \phi \) and \(b=\sin \phi \). In the orientation of Example [fcap-0038], its vector action has angle \(-2\phi \); hence the map is a twofold circle cover. The formal simple-connectedness theorem therefore has exactly the lower bound needed here; the universal-cover claim combines it with the separately established covering.
Bivectors and the orthogonal Lie algebra [fcap-000M]AGENTDRAFTED
Bivectors and the orthogonal Lie algebra [fcap-000M]AGENTDRAFTED
The second exterior power singled out by the PBW filtration has a second life inside the Clifford algebra. Its half-commutators are closed under the commutator bracket, and their action on generators is exactly the infinitesimal orthogonal action. A polar-dual basis then reconstructs a general skew lift; the Killing form specializes that calculation to the adjoint action.
§ [ca-0001]
Convention. Bivector normalizations [meinrenken2013clifford, Section 2.2.5, Proposition 2.5, p. 33] [fcap-000N]
L∃∀NAGENTDRAFTED
Convention. Bivector normalizations [meinrenken2013clifford, Section 2.2.5, Proposition 2.5, p. 33] [fcap-000N]
L∃∀NAGENTDRAFTED
Meinrenken works throughout this chapter with finite-dimensional vector spaces over a characteristic-zero field. The cards below retain his normalization and formulas but follow TauCeti's extensions. Each card states the commutative-ring, module, invertible-\(2\), finite-dimensional, or nondegeneracy assumptions it needs.
Meinrenken starts with a symmetric bilinear form \(B\) and the relation \[uv+vu=2B(u,v)1.\] For the associated quadratic form \(Q(v)=B(v,v)\), the polar form used here is \(B_Q=2B\).
Meinrenken's quantization formula and the half-commutator agree: \[q(u\wedge v)=uv-B(u,v)1 =\frac 12(uv-vu)=:\beta (u,v).\] The induced action on a vector is \[[\beta (u,v),x] =B_Q(v,x)u-B_Q(u,x)v =2\bigl (B(v,x)u-B(u,x)v\bigr ).\] This is Meinrenken's formula \(-2\iota _{B(x,-)}(u\wedge v)\) and Kostant's formula \(-2\iota _x(u\wedge v)\) in the corresponding contraction convention [kostant1997clifford, Section 2.4, (12) and Theorem 8, pp. 283, 286]. The factor of two belongs to the passage from \(B\) to the unhalved polar form \(B_Q\); it is not an additional rescaling of \(\beta \).
Definition. Clifford bivector [meinrenken2013clifford, Section 2.2.5, Proposition 2.5, p. 33] [fcap-000O]
L∃∀NAGENTDRAFTED
Definition. Clifford bivector [meinrenken2013clifford, Section 2.2.5, Proposition 2.5, p. 33] [fcap-000O]
L∃∀NAGENTDRAFTED
For the formalized extension described in Convention [fcap-000N], let \(R\) be a commutative ring in which \(2\) is invertible, let \(M\) be an \(R\)-module, and let \(Q\) be a quadratic form on \(M\). The Clifford bivector of \(u,v\in M\) is \[\beta _Q(u,v)=\frac 12\bigl (\iota (u)\iota (v)-\iota (v)\iota (u)\bigr ).\] It is alternating in \(u\) and \(v\), so it induces a linear map \[\beta _Q:\bigwedge _R^2M\longrightarrow \mathcal {C}\kern -2pt\ell (Q).\] The exterior model is a left inverse on its image: \[\operatorname {equivExterior}_Q\bigl (\beta _Q(z)\bigr )=z \qquad (z\in \bigwedge _R^2M).\] Hence \(\beta _Q\) is injective.
Lemma. A bivector acts by an infinitesimal rotation [meinrenken2013clifford, Section 2.2.10, Theorem 2.1, pp. 39--40] [fcap-000P]
L∃∀NAGENTDRAFTED
Lemma. A bivector acts by an infinitesimal rotation [meinrenken2013clifford, Section 2.2.10, Theorem 2.1, pp. 39--40] [fcap-000P]
L∃∀NAGENTDRAFTED
For \(u,v,x\in M\), the commutator of the bivector with a Clifford generator is \[[\beta _Q(u,v),\iota (x)] =\iota \left (B_Q(v,x)u-B_Q(u,x)v\right ).\] The endomorphism \[A_{u\wedge v}(x)=B_Q(v,x)u-B_Q(u,x)v\] is skew-adjoint for \(B_Q\), since \[B_Q(A_{u\wedge v}x,y)+B_Q(x,A_{u\wedge v}y)=0.\] Thus commutation by a degree-two Clifford element preserves the generating module and realizes the elementary infinitesimal orthogonal transformation attached to \(u\wedge v\).
Proof.
Proof.
Expand the half-commutator and move \(\iota (x)\) past \(\iota (u)\) and \(\iota (v)\) using the Clifford relation. The cubic terms cancel; the two polar terms combine to the displayed generator. Symmetry of \(B_Q\) then makes the skew-adjointness equation cancel in pairs.
Theorem. Exterior bivectors are the quadratic Clifford Lie algebra [meinrenken2013clifford, Section 2.2.10, Theorem 2.1, pp. 39--40] [fcap-000Q]
L∃∀NAGENTDRAFTED
Theorem. Exterior bivectors are the quadratic Clifford Lie algebra [meinrenken2013clifford, Section 2.2.10, Theorem 2.1, pp. 39--40] [fcap-000Q]
L∃∀NAGENTDRAFTED
Over the commutative ring and module of Definition [fcap-000O], let \(\mathfrak {cl}^{(2)}(Q)\) be the submodule of \(\mathcal {C}\kern -2pt\ell (Q)\) spanned by the elements \(\beta _Q(u,v)\). This is TauCeti's module-general extension of Meinrenken's characteristic-zero vector-space construction. The commutator formula of Lemma [fcap-000P], together with the Jacobi identity, shows that this submodule is closed under commutators. Transporting its bracket across \(\beta _Q\) gives a Lie algebra structure on \(\bigwedge _R^2M\) and a Lie equivalence \[\bigwedge _R^2M\simeq _{\mathrm {Lie}}\mathfrak {cl}^{(2)}(Q).\] On a decomposable bivector the equivalence is exactly \[u\wedge v\longmapsto \frac 12(uv-vu).\] No choice of basis enters this identification.
Theorem. Quadratic elements realize the orthogonal Lie algebra [meinrenken2013clifford, Section 2.2.10, Proposition 2.12, p. 40] [fcap-000R]
L∃∀NAGENTDRAFTED
Theorem. Quadratic elements realize the orthogonal Lie algebra [meinrenken2013clifford, Section 2.2.10, Proposition 2.12, p. 40] [fcap-000R]
L∃∀NAGENTDRAFTED
Meinrenken states this realization over a characteristic-zero field. TauCeti proves the extension below over any field of characteristic different from \(2\). Let \(K\) be such a field, let \(V\) be finite-dimensional, and let \(Q\) be nondegenerate. Write \(\mathfrak {so}(V,B_Q)\) for the Lie algebra of endomorphisms skew-adjoint for the polar form. Then commutation on generators gives a Lie equivalence \[\mathfrak {so}(V,B_Q)\simeq _{\mathrm {Lie}}\mathfrak {cl}^{(2)}(Q).\] If \(A\in \mathfrak {so}(V,B_Q)\) corresponds to \(z_A\in \mathfrak {cl}^{(2)}(Q)\), then \[[z_A,\iota (x)]=\iota (Ax)\qquad (x\in V).\] Combining this equivalence with Theorem [fcap-000Q] gives the basis-free chain \[\bigwedge _K^2V\simeq _{\mathrm {Lie}}\mathfrak {so}(V,B_Q) \simeq _{\mathrm {Lie}}\mathfrak {cl}^{(2)}(Q).\] Kostant identifies the same degree-two subspace with \(\operatorname {Lie}(\operatorname {Spin}(V))\) and the first equivalence with the differential of the double cover [kostant1997clifford, Section 2.4, Theorem 8, pp. 286--287].
Example. An elementary skew matrix [meinrenken2013clifford, Section 2.2.10, Proposition 2.12, p. 40] [fcap-000S]
L∃∀NAGENTDRAFTED
Example. An elementary skew matrix [meinrenken2013clifford, Section 2.2.10, Proposition 2.12, p. 40] [fcap-000S]
L∃∀NAGENTDRAFTED
This coordinate example specializes TauCeti's extension of the characteristic-zero construction summarized in Convention [fcap-000N]. Take \(V=R^n\) with the standard sum-of-squares quadratic form, and let \(e_i,e_j\) be distinct coordinate vectors. Under the standard-coordinate realization, \[e_i\wedge e_j\longmapsto 2(E_{ij}-E_{ji}).\] Thus its action on \(x=(x_k)\) is \[x\longmapsto 2x_j e_i-2x_i e_j.\] The factor \(2\) is the polar-form normalization from Convention [fcap-000N]: for the sum-of-squares form, \(B_Q(x,y)=2\sum _kx_ky_k\). The displayed matrix is the standard-coordinate specialization of the basis-free isomorphism in Meinrenken's proposition. Dividing the skew matrix by two would correspond to using the associated bilinear form \(B_Q/2\) instead.
Theorem. Reconstructing a skew Clifford lift in polar-dual coordinates [fcap-001Z]
L∃∀NAGENTDRAFTED
Theorem. Reconstructing a skew Clifford lift in polar-dual coordinates [fcap-001Z]
L∃∀NAGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible, \(V\) a finite-dimensional \(K\)-space, and \(Q\) a nondegenerate quadratic form. Write \(B_Q\) for its unhalved polar form. For a basis \((b_i)\) let \((d_i)\) be its \(B_Q\)-dual basis, and let \(f\in \mathfrak {so}(V,B_Q)\). The quadratic Clifford element \(z_f=\operatorname {soEquivQuadratic}(f)\) has the coordinate expression \[z_f=\frac 12\sum _i\beta _Q\bigl (f(b_i),d_i\bigr ),\] where \(\beta _Q(u,v)=\tfrac 12(\iota (u)\iota (v)-\iota (v)\iota (u))\) is the bivector normalization of Convention [fcap-000N].
[goodman2009symmetry, Definition 6.1.1(C1), p. 302] uses the complex Clifford relation \[\{\gamma (u),\gamma (v)\}=\beta (u,v)1.\] Thus their \(\beta \) is \(B_Q\), with \(Q(v)=\beta (v,v)/2\).
[goodman2009symmetry, Section 6.2.1, Lemmas 6.2.1--2 and (6.13), pp. 312--313] gives the complex, nondegenerate basis-free construction through \(R_{a,b}(x)=\beta (b,x)a-\beta (a,x)b\) and its half-commutator lift. The displayed polar-dual sum is the coordinate reconstruction; Tau Ceti proves it over the stated wider class of fields.
Proof.
Proof.
For \(x\in V\), dual-basis reconstruction and skew-adjointness give the two contractions \[\begin {aligned} \sum _i B_Q(d_i,x)f(b_i)&=f(x),\\ \sum _i B_Q(f(b_i),x)d_i&=-f(x). \end {aligned}\] By Lemma [fcap-000P], the commutator of the sum of bivectors with \(\iota (x)\) is the image of their difference, hence \(2\iota (f(x))\). Multiplication by \(1/2\) gives the action of \(z_f\) on every generator. The nondegenerate quadratic realization in Theorem [fcap-000R] then identifies the two quadratic elements.
Theorem. The Killing-adjoint lift has coefficient one quarter [fcap-0020]
L∃∀NAGENTDRAFTED
Theorem. The Killing-adjoint lift has coefficient one quarter [fcap-0020]
L∃∀NAGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible, and let \(L\) be a
finite-dimensional \(K\)-Lie algebra whose Killing form \(\kappa \) is
nondegenerate (the formal hypothesis is \(\operatorname {IsKilling}_K(L)\)).
Set \(Q_\kappa (y)=\kappa (y,y)\). If \((b_i)\) is a basis and
\((b_i^\vee )\) its Killing-dual basis, then for \(x\in L\) the quadratic
Clifford lift of the adjoint action is
\[\operatorname {adjointCliffordHom}(x)
=\frac 14\sum _i\beta _{Q_\kappa }
\bigl ([x,b_i],b_i^\vee \bigr ).\]
Here \(\beta _{Q_\kappa }\) is the half-commutator bivector of
Convention [fcap-000N]; the summand is the value of
CliffordAlgebra.adjointBivector_apply.
Kostant identifies the complex orthogonal Lie algebra with \(\bigwedge ^2L\) and constructs the adjoint map from a complex semisimple \(L\) using its Killing pairing [kostant1997clifford, Sections 1.1--1.2, pp. 275--276]. This supports the complex adjoint construction. The coordinate expression and its \(1/4\) normalization are the calculation here; Tau Ceti's theorem uses the stated \(\operatorname {IsKilling}\) hypothesis over a wider field class.
Proof.
Proof.
The invariance of \(\kappa \) makes \(\operatorname {ad}_x\) skew-adjoint.
Applying Theorem [fcap-001Z] to \(f=\operatorname {ad}_x\) first gives a factor
\(1/2\) with the dual basis for \(B_{Q_\kappa }\). Since
\(B_{Q_\kappa }=2\kappa \), that polar-dual basis is
\(d_i=\tfrac 12 b_i^\vee \). Bilinearity of the bivector gives the second
factor \(1/2\), and \((1/2)(1/2)=1/4\). The equality
\(B_{Q_\kappa }=2\kappa \) is the convention encoded by
TauCeti.LieAlgebra.polarBilin_killingQuadraticForm.
Remark. Infinitesimal and global Clifford symmetry [fcap-000T]AGENTDRAFTED
Remark. Infinitesimal and global Clifford symmetry [fcap-000T]AGENTDRAFTED
The quadratic Clifford Lie algebra is the infinitesimal part of the same conjugation action that produces reflections. Kostant proves that \(\bigwedge ^2V=\operatorname {Lie}(\operatorname {Spin}(V))\), that its map to \(\mathfrak {so}(V)\) is the differential of \(\operatorname {Spin}(V)\to SO(V)\), and that its commutator action extends as the corresponding derivation of the exterior algebra [kostant1997clifford, Section 2.4, Theorem 8, pp. 286--287]. Chevalley obtains the same two-vector Lie algebra inside the Clifford group [chevalley1954algebraic, II.2.9, pp. 67--68].
The cards above identify the algebraic Lie layer and reconstruct its lifts in coordinates. They do not construct Lie-group structures or identify a differential of a Lie-group covering map. The module-action card that follows uses the quadratic lift; the global orthogonal group is reached elsewhere by finite products of reflections.
Theorem. An orthogonal Lie action lifts to every Clifford module [kostant1997clifford, Section 3.1, pp. 294--295] [fcap-001O]
L∃∀NAGENTDRAFTED
Theorem. An orthogonal Lie action lifts to every Clifford module [kostant1997clifford, Section 3.1, pp. 294--295] [fcap-001O]
L∃∀NAGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible, let \(V\) be finite-dimensional, and let \(Q\) be nondegenerate. Suppose a \(K\)-Lie algebra \(L\) acts orthogonally on \(V\) through \[\theta :L\longrightarrow \mathfrak {so}(V,B_Q),\] and let \(\rho :\mathcal {C}\kern -2pt\ell (Q)\to \operatorname {End}_K(S)\) be any Clifford module. The equivalence of Theorem [fcap-000R] lifts \(\theta \) to quadratic Clifford elements; composing with \(\rho \) gives a Lie representation \[\rho _{\mathcal {C}\kern -2pt\ell }:L\longrightarrow \operatorname {End}_K(S),\qquad \rho _{\mathcal {C}\kern -2pt\ell }(y)=\rho \bigl (\operatorname {soEquivQuadratic}(\theta (y))\bigr ).\] Kostant constructs this lift for a complex reductive group representation and then lets its quadratic elements act on the spin module. The formalized statement isolates the algebraic mechanism over the stated field and for an arbitrary Clifford module; it does not assert that \(\theta \) is a differential of a group representation.
Proposition. Left Clifford multiplication is not the commutator action [fcap-003E]AGENTDRAFTED
Proposition. Left Clifford multiplication is not the commutator action [fcap-003E]AGENTDRAFTED
Let \(\mathfrak g\) be a finite-dimensional complex semisimple Lie algebra with Killing form \(\kappa \), and put \(Q_\kappa (x)=\kappa (x,x)\). If \((b_i)\) is a basis and \((b_i^\vee )\) its Killing-dual basis, the normalized quadratic lift of the adjoint action is \[\delta (x)=\frac 14\sum _i \beta _{Q_\kappa }([x,b_i],b_i^\vee )\in \mathcal {C}\kern -2pt\ell (Q_\kappa )^0.\] The coefficient is the one derived in Theorem [fcap-0020]: the polar form is \(B_{Q_\kappa }=2\kappa \), so the polar-dual basis contributes one factor \(1/2\), and the general lift contributes the other. This is a grade-two element, not the canonical generator \(\iota _{Q_\kappa }(x)\).
There are two natural actions on the same Clifford vector space: \[L_x(c)=\delta (x)c,\qquad D_x(c)=\delta (x)c-c\delta (x).\] If \(R_a(c)=ca\), then \[D_x=L_x-R_{\delta (x)},\qquad [L_x,R_a]=0.\] Under equivariant Clifford antisymmetrization, \(D\) is the derivation extension of the adjoint action to \(\bigwedge \mathfrak g\). The action \(L\) is instead left multiplication on the Clifford algebra. On matrix coordinates \(\operatorname {End}(S)\simeq S\otimes S^*\), it acts on the \(S\) factor and leaves \(S^*\) as a multiplicity space.
TauCeti defines the selected left action and proves these comparisons
in
CliffordAlgebra.kostantLieModule
CliffordAlgebra.kostant_lie_def
CliffordAlgebra.kostant_lie_sub_mul
CliffordAlgebra.kostantRightMul.
The generic module lift in Theorem [fcap-001O] supplies the same algebraic
mechanism, but it does not identify the left action with the exterior
derivation action.
[kostant1997clifford, Sections 3.1 and 5.2, pp. 294 and 311] defines the left action through this quarter-normalized lift and separately identifies the commutator with the exterior extension. [panyushev2001exterior, Section 2, internal preprint pp. 7--8] studies the exterior/spin action under the same complex semisimple hypotheses. The following example shows why their roles cannot be exchanged.
Example. For \(\mathfrak {sl}_2\), the two Clifford actions have different constituents [fcap-003F]AGENTDRAFTED
Example. For \(\mathfrak {sl}_2\), the two Clifford actions have different constituents [fcap-003F]AGENTDRAFTED
Take the basis \(e,f,h\) of \(\mathfrak {sl}_2(\mathbb C)\) with \[[h,e]=2e,\qquad [h,f]=-2f,\qquad [e,f]=h.\] The Killing form satisfies \(\kappa (e,f)=4\) and \(\kappa (h,h)=8\). Hence the Clifford relations are \[e^2=f^2=0,\qquad ef+fe=8,\qquad h^2=8,\qquad he=-eh,\quad hf=-fh.\] Substitution in the lift of Proposition [fcap-003E] gives \[E=\delta (e)=\frac {he}{8},\qquad F=\delta (f)=\frac {fh}{8},\qquad H=\delta (h)=\frac {ef-fe}{8}=\frac {ef}{4}-1.\] Direct Clifford multiplication yields \[E^2=F^2=0,\qquad H^2=1,\qquad EF=\frac {1+H}{2},\qquad FE=\frac {1-H}{2}.\] Thus \(E,F,EF,FE\) are the four matrix units of the lifted \(\mathfrak {sl}_2\) action.
For left multiplication, the \(H=+1\) and \(H=-1\) subspaces are interchanged by \(F\) and \(E\); the two maps are inverse on the corresponding projected spaces because \(EF\) and \(FE\) are their identity projectors. They have equal dimension, and \(\dim \mathcal {C}\kern -2pt\ell (Q_\kappa )=8\), so each has dimension four. Choosing a basis of the positive space and its \(F\)-images displays \[(\mathcal {C}\kern -2pt\ell (Q_\kappa ),L)\simeq 4V_1,\] four copies of the standard two-dimensional module.
For the commutator action \(D\), antisymmetrization identifies the same vector space with \(\bigwedge \mathfrak {sl}_2\). The exterior powers are \[\bigwedge ^0\mathfrak g\simeq V_0,\qquad \bigwedge ^1\mathfrak g\simeq V_2,\qquad \bigwedge ^2\mathfrak g\simeq V_2,\qquad \bigwedge ^3\mathfrak g\simeq V_0,\] where the middle identification uses the bracket and the last uses the invariant volume. Therefore \[(\mathcal {C}\kern -2pt\ell (Q_\kappa ),D)\simeq 2V_0\oplus 2V_2.\] The dimensions agree but the characters do not. [kostant1997clifford, Theorem 39, pp. 312--313] gives the first answer through Kostant's primary-type theorem. [panyushev2001exterior, Example 2.5(1), internal preprint p. 8] independently gives the exterior decomposition. The displayed matrix-unit calculation directly verifies which action produces which answer.
Theorem. The left Killing-Clifford module is primary of type \(V_\rho \) [fcap-003G]AGENTDRAFTED
Theorem. The left Killing-Clifford module is primary of type \(V_\rho \) [fcap-003G]AGENTDRAFTED
Let \(\mathfrak g\) be a finite-dimensional complex semisimple Lie algebra of rank \(\ell \). Choose positive roots \(\Phi ^+\), put \(r=\lvert \Phi ^+\rvert \), and write \(\rho =\frac 12\sum _{\alpha >0}\alpha \). Then \[\dim \mathfrak g=\ell +2r.\] Give \(\mathcal {C}\kern -2pt\ell (Q_\kappa )\) the left action \(L\) of Proposition [fcap-003E]. As a \(\mathfrak g\)-module it is \[\mathcal {C}\kern -2pt\ell (Q_\kappa )\simeq 2^{\ell +r}V_\rho .\] Here the exponent is the multiplicity; \(\dim V_\rho =2^r\), so the total dimension is \(2^{\ell +2r}\), as required. For the zero Lie algebra this reads as the one-dimensional trivial module.
First compute the spinor constituent. The weights of the adjoint orthogonal module are zero with multiplicity \(\ell \) and the roots in opposite pairs. The exterior spinor character is therefore \[\operatorname {ch}S= 2^{\lfloor \ell/2\rfloor } \prod _{\alpha >0} \left (e^{\alpha/2}+e^{-\alpha/2}\right ).\] The Weyl character formula for highest weight \(\rho \), together with the Weyl denominator identity applied to \(2\rho \) and divided by the ordinary denominator, gives \[\operatorname {ch}V_\rho =e^\rho \prod _{\alpha >0}(1+e^{-\alpha }) =\prod _{\alpha >0} \left (e^{\alpha/2}+e^{-\alpha/2}\right ).\] Complete reducibility and independence of irreducible characters now give \[S\simeq 2^{\lfloor \ell/2\rfloor }V_\rho .\] [panyushev2001exterior, Example 2.5(1), internal preprint p. 8] records this adjoint specialization under the complex semisimple hypotheses. The character calculation above supplies the comparison in the fixed normalization rather than substituting that conclusion without proof.
It remains to pass from a spinor carrier to the full Clifford algebra. If \(n=\ell +2r\) is even, the matrix range of Theorem [fcap-002V] gives \[\mathcal {C}\kern -2pt\ell (Q_\kappa )\simeq \operatorname {End}(S)\simeq S\otimes S^*.\] Left multiplication acts on the first factor, so \(S^*\) is a trivial multiplicity space of dimension \(2^{n/2}\). If \(n\) is odd, the odd structure of Proposition [fcap-002W] gives two matrix blocks \(\operatorname {End}(S_1)\oplus \operatorname {End}(S_2)\). The two full Clifford actions differ, but their restrictions to the even algebra are equivalent; since \(\delta (\mathfrak g)\) is even, both blocks contain the same \(\mathfrak g\)-module. Their combined multiplicity-space dimension is \(2\cdot 2^{(n-1)/2}=2^{\lceil n/2\rceil }\).
In both parity cases the multiplicity of \(V_\rho \) is \[2^{\lceil n/2\rceil } 2^{\lfloor \ell/2\rfloor } =2^{\ell +r}.\] This proves the displayed decomposition. [kostant1997clifford, Theorem 39, pp. 312--313] independently proves the exact left-regular primary-type statement by a highest-weight right ideal. TauCeti formalizes the selected left action and its commuting right multiplications, but the character, matrix-block, and multiplicity synthesis here is not a packaged formal theorem.
The conclusion is a module decomposition only. It does not assert the stronger algebra factorization \(\operatorname {End}(V_\rho )\otimes \mathcal {C}\kern -2pt\ell (P)\), identify the full commutant, or invoke the Hopf--Koszul--Samelson primitive algebra. The normal-ordered \(\mathfrak {gl}_N\) calculation in the separate CAR section uses a trace shift and is not a substitute for this Killing-adjoint theorem.
Theorem. The invariant algebra is the internal commutant [fcap-003P]AGENTDRAFTED
Theorem. The invariant algebra is the internal commutant [fcap-003P]AGENTDRAFTED
Let \(\mathfrak g\) be complex semisimple of rank \(\ell \), with \(r\) positive roots and \(\rho \) their half-sum. Put \(A=\mathcal {C}\kern -2pt\ell (Q_\kappa )\), where \(Q_\kappa (x)=\kappa (x,x)\), and use the lift \(\delta \) of Proposition [fcap-003E]. Define the unital algebra \(E=\delta (U(\mathfrak g))\subseteq A^0\) and the commutator invariants \[J=\{a\in A:[\delta (x),a]=0\text { for every }x\in \mathfrak g\}.\] Then \(J=\operatorname {Cent}_A(E)\), \(E\simeq \operatorname {End}(V_\rho )\), and multiplication is an isomorphism of ordinary complex algebras \[E\otimes J\longrightarrow A,\qquad e\otimes j\longmapsto ej.\] In particular, \(\dim J=2^\ell \). These assertions include the zero Lie algebra, where \(A=E=J=\mathbb C\).
An element commutes with the generators \(\delta (\mathfrak g)\) exactly when it commutes with their unital associative algebra, proving the centralizer assertion. Set \(d=2^{\lfloor \ell /2\rfloor }\). The spinor calculation in Theorem [fcap-003G] gives \(S\simeq V_\rho \otimes \mathbb C^d\). The associative algebra generated by an irreducible complex representation is its full endomorphism algebra (Burnside's theorem). Thus the image of \(U(\mathfrak g)\) on \(S\) is \(\operatorname {End}(V_\rho )\otimes 1\). This is the primary-representation calculation in [kostant1997clifford, equations (74)--(76), p. 295].
If \(\ell \) is even, then \(\dim \mathfrak g=\ell +2r\) is even, and Theorem [fcap-002V] identifies \(A\) with \(\operatorname {End}(S)\). Matrix units in \(\operatorname {End}(V_\rho )\) show that its commutant on \(V_\rho \otimes \mathbb C^d\) is \(1\otimes \operatorname {End}(\mathbb C^d)\): commuting with diagonal units forces a block-diagonal operator, and commuting with off-diagonal units makes all its diagonal blocks equal. Consequently \[J\simeq \operatorname {End}(\mathbb C^d),\qquad E\otimes J\simeq \operatorname {End}(V_\rho \otimes \mathbb C^d)=A.\] This also gives \(\dim J=d^2=2^\ell \).
If \(\ell \) is odd, Proposition [fcap-002W] identifies \(A\) with \(\operatorname {End}(S_+)\oplus \operatorname {End}(S_-)\). The two spinor restrictions to \(A^0\) are equivalent and faithful. After identifying them, \(E\subseteq A^0\) is the diagonal copy of \(\operatorname {End}(V_\rho )\otimes 1\). The same matrix-unit argument in each block gives \[J\simeq \operatorname {End}(\mathbb C^d) \oplus \operatorname {End}(\mathbb C^d).\] Multiplication \(E\otimes J\to A\) is the preceding matrix isomorphism in each of the two summands, and \(\dim J=2d^2=2^\ell \). This proves both parity cases without assuming that the full odd-dimensional Clifford algebra is simple. [kostant1997clifford, Propositions 17--20, pp. 294--297] gives this centralizer factorization for any primary spin representation.
Under the commutator action, \(\mathfrak g\) acts trivially on \(J\) and by conjugation on \(E\). Equivariant antisymmetrization from Proposition [fcap-003E] therefore yields the exterior-module consequence \[\bigwedge \mathfrak g\simeq 2^\ell (V_\rho \otimes V_\rho ^*).\] This multiplicity concerns the commutator action; the left-action multiplicity in Theorem [fcap-003G] is \(2^{\ell +r}\). The algebra factorization and its proof here are not a packaged formal theorem.
Remark. Three different commutants for the left Clifford action [fcap-003Q]AGENTDRAFTED
Remark. Three different commutants for the left Clifford action [fcap-003Q]AGENTDRAFTED
Keep the hypotheses and notation of Theorem [fcap-003P], and let \(L_x(c)=\delta (x)c\). The internal centralizer \(J\subseteq A\), the right-multiplication operators on \(A\), and the full algebra of \(\mathfrak g\)-module endomorphisms of \((A,L)\) have distinct roles.
Left multiplication by \(j\in J\) commutes with every \(L_x\). Right multiplication by any \(a\in A\) also commutes with every \(L_x\), purely by associativity. Thus there are injective algebra maps \[J\longrightarrow \operatorname {End}_{\mathfrak g}(A,L), \qquad j\longmapsto (c\longmapsto jc),\] \[A^{\mathrm {op}}\longrightarrow \operatorname {End}_{\mathfrak g}(A,L), \qquad a\longmapsto (c\longmapsto ca).\] Evaluation at \(1\) proves injectivity. The opposite algebra in the second map records the reversed order of right compositions.
By Theorem [fcap-003G], \((A,L)\simeq V_\rho \otimes \mathbb C^m\) with \(m=2^{\ell +r}\). Schur's lemma and the same block calculation as in Theorem [fcap-003P] give \[\operatorname {End}_{\mathfrak g}(A,L) \simeq M_m(\mathbb C).\] The dimensions of the three algebras are therefore \[\dim J=2^\ell ,\qquad \dim A^{\mathrm {op}}=2^{\ell +2r},\qquad \dim \operatorname {End}_{\mathfrak g}(A,L)=2^{2\ell +2r}.\] For \(\mathfrak g=\mathfrak {sl}_2\), these are \(2\), \(8\), and \(16\), respectively: \(J\simeq \mathbb C\oplus \mathbb C\), while \(\operatorname {End}_{\mathfrak g}(A,L)\simeq M_4(\mathbb C)\). The four-copy left-module calculation is explicit in Example [fcap-003F]. For every nonzero complex semisimple \(\mathfrak g\), the dimensions show that right multiplications form a proper subalgebra of the full module commutant. They do not by themselves identify that commutant.
Theorem. Primitive invariants and their quadratic form [fcap-003R]AGENTDRAFTED
Definition [ca-000J]
Theorem. Primitive invariants and their quadratic form [fcap-003R]AGENTDRAFTED
Let \(\mathfrak g\) be finite-dimensional complex semisimple of rank \(\ell \). Write \(I=(\bigwedge \mathfrak g)^{\mathfrak g}\) for the adjoint invariants and \(I^+\) for their positive-degree part. Extend the Killing form \(\kappa \) to the determinant pairing \(\langle -,-\rangle \) on each exterior degree, with different degrees orthogonal. Let \(\pi :\bigwedge \mathfrak g\to I\) be the invariant projection along \(\mathfrak g\mathbin {\cdot }\bigwedge \mathfrak g\), the span of all adjoint derivatives. The coproduct on \(I\) is \[\Delta =(\pi \otimes \pi )\Delta _0|_I,\] where \(\Delta _0(x)=x\otimes 1+1\otimes x\) for \(x\in \mathfrak g\). It is this projected coproduct that defines primitive invariants: \[P=\{p\in I:\Delta p=p\otimes 1+1\otimes p\} =I^+\cap ((I^+)^2)^\perp .\] The ordinary exterior coproduct need not take \(I\) into \(I\otimes I\). The Lie-homology construction makes \(I\), with the displayed \(\Delta \), a graded super Hopf algebra; multiplication on \(I\otimes I\) uses the Koszul rule \((a\otimes b)(c\otimes d)=(-1)^{\lvert b\rvert \lvert c\rvert }ac\otimes bd\) for homogeneous elements. The coproduct is dual to the wedge product. This is the input from [meinrenken2013clifford, Theorem 10.1 and Proposition 10.11, pp. 240--241].
The Hopf--Koszul--Samelson theorem says that inclusion extends to \[\bigwedge P\xrightarrow {\sim }I.\] Here every primitive has odd exterior degree. Indeed, a nonzero homogeneous even primitive \(p\) would have a least nilpotent power \(p^k=0\); the component \(k p\otimes p^{k-1}\) of \(\Delta (p^k)\) could not vanish in characteristic zero. The orthogonal decomposition \(I^+=P\oplus (I^+)^2\) then proves generation: substituting it repeatedly expresses every element as a polynomial in \(P\), since the augmentation ideal is nilpotent. For independence, contraction by a primitive acts as an odd derivation on \(I\), and contraction of two primitives is a scalar. The first assertion is dual to \(\Delta \) preserving multiplication; the second follows from \(P\perp (I^+)^2\). Successive contractions by a dual primitive basis extract the coefficients of an exterior-monomial relation, starting with the largest number of factors. All coefficients vanish. This proves the stated isomorphism; compare [meinrenken2013clifford, Theorem 10.2 and Proposition 10.13, pp. 242--243]. By Theorem [fcap-003P], \(\dim I=2^\ell \), so \(\dim P=\ell \).
For \(x\in \mathfrak g\), let \(\iota _x\) be contraction using \(\kappa \), and set \(\iota _{x_1\wedge \cdots \wedge x_k}=\iota _{x_1}\cdots \iota _{x_k}\). Exterior reversion is \(\operatorname {rev}(u)=(-1)^{k(k-1)/2}u\) on degree \(k\). The form relevant to Clifford multiplication is \[B_\wedge (u,v)=(\iota _u v)_0 =\langle \operatorname {rev}(u),v\rangle ,\qquad Q_P(p)=B_\wedge (p,p).\] In particular, on primitive degree \(2m+1\), \(B_\wedge (p,q)=(-1)^m\langle p,q\rangle \). The Clifford polar relation for \(Q_P\) is therefore \(pq+qp=2B_\wedge (p,q)\), with the same generator-square convention as \(Q_\kappa (x)=\kappa (x,x)\).
This restriction of \(B_\wedge \) to \(P\) is nondegenerate. Choose a compact real form. Its Killing form is negative definite; on exterior degree \(k\), the determinant pairing is \((-1)^k\) times a positive definite real form. The subspace \(P\) is graded and preserved by compact conjugation, so the determinant pairing and its degreewise sign multiple \(B_\wedge \) are nondegenerate there. This also explains the normalization change from [meinrenken2013clifford, Section 11.3, p. 260], which starts with a positive compact form. Replacing that form by its negative preserves the graded orthogonal subspaces while changing the indicated degree signs.
Theorem. Kostant's primitive Clifford factorization [fcap-003S]AGENTDRAFTED
Theorem. Kostant's primitive Clifford factorization [fcap-003S]AGENTDRAFTED
With \(P,Q_P\) as in Theorem [fcap-003R], put \(A=\mathcal {C}\kern -2pt\ell (Q_\kappa )\) and \(J=A^{\mathfrak g}\) for the commutator invariants of Theorem [fcap-003P]. Let \(q:\bigwedge \mathfrak g\to A\) be antisymmetrization. Then \(p\mapsto q(p)\) extends to an isomorphism of complex superalgebras \[\mathcal {C}\kern -2pt\ell (Q_P)\xrightarrow {\sim }J.\] Consequently multiplication gives \[\operatorname {End}(V_\rho )\otimes \mathcal {C}\kern -2pt\ell (Q_P) \xrightarrow {\sim }\mathcal {C}\kern -2pt\ell (Q_\kappa ).\] The endomorphism factor is purely even. Thus the displayed tensor product has the ordinary multiplication as well as the superalgebra interpretation. The proof below establishes the Clifford relation and generation separately.
We use the Lie-homology Hodge decomposition \[\bigwedge \mathfrak g =I\oplus \operatorname {im}d\oplus \operatorname {im}\partial =I\oplus (\mathfrak g\mathbin {\cdot }\bigwedge \mathfrak g),\] orthogonal for \(B_\wedge \). Here \(\partial \) is the Lie-homology boundary and \(d\) is the cohomology differential transported by \(\kappa \). The needed contraction identities are \[\iota _{\operatorname {im}d}I\subseteq \operatorname {im}\partial , \qquad \iota _{\operatorname {im}\partial }I\subseteq \operatorname {im}d,\] \[\ker \partial \wedge \operatorname {im}\partial \subseteq \mathfrak g\mathbin {\cdot }\bigwedge \mathfrak g.\] Proposition 10.8 and Lemmas 10.4--10.5 of [meinrenken2013clifford, pp. 238--239] give these identities. Changing the compact form's sign multiplies contractions and the transported differential by degreewise nonzero scalars, so the displayed ranges and identities also hold for \(\kappa \).
Choose a homogeneous basis \(\tau _a\) of the exterior algebra adapted to the three Hodge summands, and its \(B_\wedge \)-dual basis \(\tau ^a\). For odd \(p\in P\) and \(q'\in P\), the Clifford product formula is \[q^{-1}(q(p)q(q'))= \sum _a\iota _{\tau _a}p\wedge \iota _{\tau ^a}q'.\] This is the contraction expansion in [meinrenken2013clifford, equation (11.10), p. 260]; using the \(B_\wedge \)-dual basis incorporates the reversion signs. Terms indexed by \(\operatorname {im}d\) lie in \(\mathfrak g\mathbin {\cdot }\bigwedge \mathfrak g\) by the two contraction identities and the boundary-product identity. Terms indexed by \(\operatorname {im}\partial \) lie in \(\operatorname {im}d\), because \(d\) is a derivation and the wedge product of two exact elements is exact. Their combined sum is zero: the full product and the terms indexed by \(I\) are invariant, whereas the remaining terms lie in the complementary Hodge summand.
Take a homogeneous basis \(p_1,\ldots ,p_\ell \) of \(P\) and its \(B_\wedge \)-dual basis \(p^1,\ldots ,p^\ell \). The HKS monomials give a basis of \(I\). Repeated primitive contractions of a primitive vanish after the first contraction, which is already scalar. Moreover, \(\mathbb C\oplus P\oplus (I^+)^2\) is orthogonal, so the dual vectors belonging to the single primitives are \(p^i\). Only the constant monomial and the single primitives survive in the preceding sum. Hence \[q^{-1}(q(p)q(q')) =p\wedge q'+\sum _i B_\wedge (p_i,p)B_\wedge (p^i,q') =p\wedge q'+B_\wedge (p,q').\] Both primitives are odd, so swapping them cancels their wedge products and yields \[q(p)q(q')+q(q')q(p)=2B_\wedge (p,q').\] This is Kostant's primitive Clifford relation in the fixed sign convention; see [meinrenken2013clifford, Theorem 11.6 and equation (11.13), pp. 260--261] and [kostant1997clifford, Theorem 35, pp. 306--308].
The universal property now gives a homomorphism \(\mathcal {C}\kern -2pt\ell (Q_P)\to J\). To prove generation, order the HKS monomials by their total exterior degree. The product \(q(p_{i_1})\cdots q(p_{i_s})\) has leading exterior term \(p_{i_1}\wedge \cdots \wedge p_{i_s}\) under \(q^{-1}\); its other terms have lower degree, by the Clifford filtration. They are invariant, hence linear combinations of lower-degree HKS monomials. Induction therefore puts every \(q(p_{i_1}\wedge \cdots \wedge p_{i_s})\) in the generated algebra. This proves surjectivity. Both algebras have dimension \(2^\ell \), so the map is an isomorphism. It preserves parity, since all elements of \(P\) have odd degree.
Finally, substitute this identification of \(J\) in the multiplication isomorphism of Theorem [fcap-003P]. This yields the claimed factorization, also displayed in [meinrenken2013clifford, equation (11.14), p. 262]. For \(\mathfrak {sl}_2\), \(P\) has dimension one in exterior degree three. As an ordinary algebra, its nondegenerate complex Clifford algebra is \(\mathbb C\oplus \mathbb C\); the underlying ordinary algebra factorization becomes \(M_2(\mathbb C)\oplus M_2(\mathbb C)\), in agreement with Remark [fcap-003Q]. The primitive relation, HKS argument, and factorization here are mathematical proofs without a packaged formal theorem.
Proposition. Normal ordering adds a matrix-trace central character [fcap-0035]AGENTDRAFTED
Proposition. Normal ordering adds a matrix-trace central character [fcap-0035]AGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible. On \(V=M_N(K)\) take \[Q_{\mathrm {tr}}(Y)=\operatorname {Tr}(Y^2),\qquad B_{Q_{\mathrm {tr}}}(X,Y)=2\operatorname {Tr}(XY),\] and write \(d_{ij}=\iota _{Q_{\mathrm {tr}}}(E_{ij})\). The Clifford relation is \[d_{ij}d_{kl}+d_{kl}d_{ij} =2\delta _{jk}\delta _{li}.\] Let \(q(X)\) be the quadratic Clifford lift of the adjoint action \(Y\mapsto [X,Y]\). The normal-ordered lift used for the CAR module is \[D(X)=q(X)+\frac N2\operatorname {Tr}(X)1.\] On a matrix unit it has the concrete form \[D(E_{ij})=\frac 12\sum _{k=0}^{N-1}d_{ik}d_{kj}.\] Indeed, \(d_{ik}d_{kj}=\beta _{Q_{\mathrm {tr}}}(E_{ik},E_{kj}) +\delta _{ij}1\); summing the contraction term over \(k\) gives \((N/2)\delta _{ij}1\). This derives both the coefficient and its positive sign.
There are three different actions here. The ordinary exterior extension of the adjoint action is the derivation \[\delta _X(Y_1\wedge \cdots \wedge Y_r) =\sum _sY_1\wedge \cdots \wedge [X,Y_s]\wedge \cdots \wedge Y_r.\] The quadratic Clifford action is the inner derivation \([q(X),-]=[D(X),-]\). The CAR representation on the full Clifford algebra is instead left multiplication, \[\rho _{\mathrm {CAR}}(X)c=D(X)c, \qquad \rho _{\mathrm {CAR}}(X)c-cD(X)=[D(X),c].\] On the central matrix the three formulas read: \[\operatorname {ad}_I=0,\qquad q(I)=0, \qquad D(I)=\frac {N^2}{2}1.\] The left-regular carrier has dimension \(2^{N^2}\). For \(N\geq 1\) it is not an irreducible exterior spinor carrier; \(N=0\) is the one-dimensional trivial exception.
The exact identities are formalized at the pinned TauCeti revision. The normal-ordered lift, its matrix-unit and generator formulas, and the left-action comparison have the field and inverse-two hypotheses stated above. They do not identify this module with an irreducible spinor representation.
[pressley1986loop, Section 12.1, pp. 230--233] let the determinant-square-root cover of \(U(W)\) act on \(\bigwedge ^kW\) by \(u^{-1}\bigwedge ^k(A)\), with \(u^2=\det A\). Differentiating first along a unitary curve gives \(d\bigwedge (X)-\frac 12\operatorname {Tr}_W(X)\) for \(X\in \mathfrak u(W)\); complexifying then gives the corresponding \(\mathfrak {gl}(W)\) formula. No arbitrary complex matrix is being presented as the derivative of a unitary curve.
[panyushev2001exterior, Section 2, Example 2.5(3), preprint pp. 8--9] works over an algebraically closed field of characteristic zero and gives the ordinary spinor correction as \(\mathbb k_{-\nu }\otimes \bigwedge W\), where \(\nu \) is half the sum of the weights with multiplicity. Evaluating \(\nu \) is half the exterior trace. These two sources agree on the ordinary minus-half-trace normalization. They do not produce the positive \((N/2)\operatorname {Tr}\) term above: the trace of \(\operatorname {ad}_X\) on \(M_N\) is zero, while that term is the contraction created by normal ordering on the full left-regular Clifford module.
Proposition. The positive CAR product has half-staircase weight [fcap-0036]AGENTDRAFTED
Proposition. The positive CAR product has half-staircase weight [fcap-0036]AGENTDRAFTED
Let \(K\) be a field in which \(2\) is invertible. Begin with \(N=2\) and put \(v_+=d_{01}\). The relations are \[d_{01}^2=d_{10}^2=0,\qquad d_{00}^2=d_{11}^2=1, \qquad d_{01}d_{10}+d_{10}d_{01}=2.\] The only raising operator is \[D(E_{01})=\frac 12(d_{00}d_{01}+d_{01}d_{11}),\] and each summand kills \(v_+\). For the diagonal operators, the same CAR relations give \[D(E_{00})v_+=\frac 32v_+,\qquad D(E_{11})v_+=\frac 12v_+.\] Thus \(v_+\) has weight \((3/2,1/2)\), and \(D(I)v_+=2v_+\). Subtracting the central correction \((N/2)\operatorname {Tr}\) leaves \((1/2,-1/2)\). In characteristic zero this is the usual \(\mathfrak {sl}_2\) value \(\rho \).
For general \(N\), order the indices as \(0<1<\cdots <N-1\) and form the lexicographically ordered product \[v_+=\prod _{0\leq i<j<N}^{\mathrm {lex}}d_{ij}.\] Every positive matrix unit is \(Q_{\mathrm {tr}}\)-null, and distinct positive matrix units are polar-orthogonal. Their Clifford generators therefore anticommute. PBW linear independence shows that the ordered product is nonzero over a field.
Let \(i<j\). In \[D(E_{ij})v_+=\frac 12\sum _kd_{ik}d_{kj}v_+,\] a term with \(k<j\) vanishes because the positive generator \(d_{kj}\) already occurs in \(v_+\). If \(k\geq j\), then \(i<k\); first anticommute \(d_{ik}\) past \(d_{kj}\), using \(i\ne j\), and the repeated positive factor \(d_{ik}\) makes the term zero. Hence every raising operator annihilates \(v_+\).
For a diagonal generator, \[D(E_{ii})v_+=\frac 12\sum _kd_{ik}d_{ki}v_+.\] The contributions for \(k<i\), \(k=i\), and \(k>i\) are respectively \(0\), \(v_+\), and \(2v_+\). Therefore \[D(E_{ii})v_+ =\frac 12\bigl (1+2|\{k:k>i\}|\bigr )v_+.\] For \(i\in \operatorname {Fin}(N)\), the weight and its quadratic-lift part are \[\lambda _i=N-i-\frac 12,\qquad \lambda _i-\frac N2=\frac {N-1}{2}-i,\qquad \sum _i\lambda _i=\frac {N^2}{2}.\] The last equality agrees with the direct central calculation \(D(I)=N^2/2\).
TauCeti defines this ordered product and proves its nonvanishing, raising equations, and diagonal weight. See the exact pinned product and PBW nonvanishing and half-staircase theorems. Nonvanishing needs a field; the highest-vector statement adds invertible \(2\). Identifying the subtracted weight with the rational staircase requires characteristic zero.
[panyushev2001exterior, Section 2, Example 2.5(1), preprint p. 8] identifies, over an algebraically closed field of characteristic zero, the reduced adjoint spin module with highest weight \(\rho \). The subtracted weight above is exactly that semisimple staircase. The added \((N/2)\operatorname {Tr}\) character records the reductive center of this normal-ordered left action. This comparison does not attribute the selected product or the full left-regular CAR module to Panyushev, and it makes no irreducibility or whole-module decomposition claim.
Differentiating and integrating Spin representations [fcap-001Q]AGENTDRAFTED
Differentiating and integrating Spin representations [fcap-001Q]AGENTDRAFTED
The quadratic Clifford construction in the preceding section is algebraic. A different bridge starts from a smooth homomorphism of Lie groups and differentiates it at the identity. The concrete Spin calculation identifies this differential with the normalized quadratic lift. For compact \(\operatorname {Spin}(n)\), \(n\geq 3\), simple connectedness then gives the reverse construction: integration of a Lie-algebra representation. Its action on the covering kernel decides whether it also represents \(SO(n)\).
Definition. The differential of a smooth homomorphism
[liu2016lie, Section 2.1, p. 9] [fcap-001R]AGENTDRAFTED
Definition. The differential of a smooth homomorphism
[liu2016lie, Section 2.1, p. 9] [fcap-001R]AGENTDRAFTED
Let \(G\) and \(H\) be finite-dimensional real Lie groups, with identities \(e_G\) and \(e_H\), and let \(\phi :G\to H\) be a smooth group homomorphism. Their Lie algebras are the tangent spaces \[\mathfrak g=T_{e_G}G, \qquad \mathfrak h=T_{e_H}H.\] The differential of \(\phi \) at the identity is the linear map \[\operatorname {Lie}(\phi )=d\phi _{e_G}: \mathfrak g\longrightarrow \mathfrak h.\] No connectedness or simply-connectedness hypothesis is needed to define this map. Those hypotheses enter the converse problem of integrating a Lie-algebra homomorphism, not the differentiation of a given smooth homomorphism.
For \(X\in \mathfrak g\), let \(\widetilde X\) be its left-invariant vector field, \[\widetilde X_g=d(L_g)_{e_G}X.\] The homomorphism identity \(\phi \circ L_g=L_{\phi (g)}\circ \phi \) gives \[d\phi _g(\widetilde X_g) =\widetilde {\operatorname {Lie}(\phi )(X)}_{\phi (g)}.\] Thus differentiation at the identity and transport by left translation are two descriptions of the same infinitesimal map.
Lemma. The differential preserves the Lie bracket
[liu2016lie, Section 2.1, p. 9] [fcap-001S]AGENTDRAFTED
Lemma. The differential preserves the Lie bracket
[liu2016lie, Section 2.1, p. 9] [fcap-001S]AGENTDRAFTED
In the setting of Definition [fcap-001R], the differential is a Lie-algebra homomorphism: \[\operatorname {Lie}(\phi )([X,Y]) =[\operatorname {Lie}(\phi )(X), \operatorname {Lie}(\phi )(Y)].\] Indeed, the left-invariant fields \(\widetilde X\) and \(\widetilde Y\) are \(\phi \)-related to the left-invariant fields determined by their images. Brackets of related vector fields are again related. Evaluating that relation at \(e_G\) gives the displayed identity.
This argument is local at the identity. In particular, bracket preservation does not require \(G\) to be connected or simply connected.
Theorem. The Lie functor [liu2016lie, Section 2.2, p. 10] [fcap-001T]AGENTDRAFTED
Theorem. The Lie functor [liu2016lie, Section 2.2, p. 10] [fcap-001T]AGENTDRAFTED
Differentiation at the identity is functorial. For smooth homomorphisms \(G\xrightarrow {\phi }H\xrightarrow {\psi }K\), the chain rule gives \[\operatorname {Lie}(\operatorname {id}_G) =\operatorname {id}_{\mathfrak g}, \qquad \operatorname {Lie}(\psi \circ \phi ) =\operatorname {Lie}(\psi )\circ \operatorname {Lie}(\phi ).\] Together with Lemma [fcap-001S], this defines a functor from Lie groups and smooth homomorphisms to Lie algebras and Lie-algebra homomorphisms.
The stronger correspondence between simply connected Lie groups and Lie algebras concerns existence and uniqueness in the reverse direction. It is not a hypothesis of these functor laws.
Theorem. Naturality of the exponential
[liu2016lie, Section 2.4, pp. 12--13] [fcap-001U]AGENTDRAFTED
Theorem. Naturality of the exponential
[liu2016lie, Section 2.4, pp. 12--13] [fcap-001U]AGENTDRAFTED
Let \(\phi :G\to H\) be a smooth Lie-group homomorphism. For every \(X\in \mathfrak g\), \[\phi (\exp _G X) =\exp _H\bigl (\operatorname {Lie}(\phi )(X)\bigr ).\] Equivalently, the square
Proof.
Proof.
The curve \(t\mapsto \phi (\exp _G(tX))\) is a one-parameter subgroup of \(H\). Its tangent vector at \(t=0\) is \(\operatorname {Lie}(\phi )(X)\). The curve \(t\mapsto \exp _H(t\operatorname {Lie}(\phi )(X))\) has the same property and the same tangent vector. Uniqueness of the one-parameter subgroup with a given tangent vector identifies the curves; setting \(t=1\) proves the formula.
Example. Differentiating a matrix representation
[liu2016lie, Sections 2.1 and 2.4, pp. 9, 12] [fcap-001V]AGENTDRAFTED
Example. Differentiating a matrix representation
[liu2016lie, Sections 2.1 and 2.4, pp. 9, 12] [fcap-001V]AGENTDRAFTED
Let \(V\) be a finite-dimensional real vector space and let \[\rho :G\longrightarrow \operatorname {GL}(V)\] be a smooth representation. Its differential is a Lie-algebra representation \[d\rho _{e_G}:\mathfrak g\longrightarrow \mathfrak {gl}(V).\] Naturality of the exponential becomes \[\rho (\exp _G X)=\exp \bigl (d\rho _{e_G}(X)\bigr ),\] where the exponential on the right is the ordinary matrix exponential. For example, for the determinant homomorphism \(\det :\operatorname {GL}_n(\mathbb R)\to \mathbb R^\times \), \[d(\det )_I(A)=\operatorname {tr}(A).\]
Remark. Why explicit smoothness changes the roadmap
[liu2016lie, Sections 2.1--2.4 and 2.8, pp. 9--13, 19--20];
[isaev2018theory, Section 3.1.2, pp. 106--107] [fcap-001W]AGENTDRAFTED
Remark. Why explicit smoothness changes the roadmap
[liu2016lie, Sections 2.1--2.4 and 2.8, pp. 9--13, 19--20];
[isaev2018theory, Section 3.1.2, pp. 106--107] [fcap-001W]AGENTDRAFTED
The constructions in Definition [fcap-001R]--Example [fcap-001V] start with a smooth homomorphism. Their tangent map, bracket law, functor laws, and exponential naturality therefore do not require a theorem that upgrades a continuous homomorphism to a smooth one. The generic theorem does not invoke the closed-subgroup theorem; that theorem belongs to the later specialization to concrete matrix subgroups. This is the dependency split recorded in TauCetiRoadmap PR 224.
The exponential input is separate from the tangent and bracket input. Likewise, the Baker--Campbell--Hausdorff calculation can first be made in a matrix or general-linear group; using it inside a particular closed matrix subgroup additionally requires the subgroup's Lie structure. Liu describes the local exponential and BCH coordinates, while Isaev--Rubakov give the matrix Campbell--Hausdorff calculation.
Tau Ceti's generic interface now defines the Lie map of a bundled smooth
monoid morphism between finite-dimensional real Lie groups
lieMap. It proves the identity and composition laws
lieMap_id, lieMap_comp, and exponential
naturality map_lieExp. These declarations act on
left-invariant derivations and require the corresponding smooth Lie-group
structures.
The generic interface does not by itself identify the differential of \(\operatorname {Spin}(Q)\to SO(Q)\) inside the vector-generated Clifford carrier. The closed-subgroup realization, tangent calculation, and quadratic-lift comparison are supplied in Proposition [fcap-0037]. Thus the generic Lie functor and the Clifford calculation retain distinct hypotheses and meet only after the actual group structure has been established.
Proposition. The differential of the actual Spin action is the quadratic lift [fcap-0037]AGENTDRAFTED
Proposition. The differential of the actual Spin action is the quadratic lift [fcap-0037]AGENTDRAFTED
Let \(V\) be a positive-dimensional finite-dimensional real vector space, and let \(Q\) be nondegenerate. Give \(\mathcal {C}\kern -2pt\ell (Q)\) its ordinary finite-dimensional topology. Inside \(\mathcal {C}\kern -2pt\ell (Q)^\times \), evenness, reverse norm one, and normalization of the embedded vector subspace are closed conditions and define a subgroup. This subgroup is the actual vector-generated \(\operatorname {Spin}(Q)\). Indeed, for any element \(x\) satisfying them, its twisted action lies in \(O(Q)\). Cartan--Dieudonne supplies a vector product \(u\) with the same twisted action. For \(z=u^{-1}x\), \[\alpha (z)\iota (v)=\iota (v)z\qquad (v\in V).\] Graded centrality makes \(z\) a nonzero scalar; no parity of \(u\) has been assumed in this step. If \(Q(w)\ne 0\), every nonzero scalar \(c\) is the two-vector product \[\iota (w)\,\iota \left (\frac {c}{Q(w)}w\right )=c1.\] Thus \(x\) is vector-generated, and its stated evenness and norm place it in Spin. The reverse inclusion is immediate from the carrier definition. The closed-subgroup theorem now gives this concrete Spin group its finite-dimensional real Lie-group structure.
For \(A\in \mathfrak {so}(V,B_Q)\), let \(b(A)\) be the normalized quadratic Clifford lift of Theorem [fcap-000R]. For every \(t\in \mathbb R\), \[g_A(t)=\exp \bigl (t b(A)\bigr )\in \operatorname {Spin}(Q), \qquad g_A(t)\,\iota (v)\,g_A(t)^{-1} =\iota \bigl (\exp (tA)v\bigr ).\] Indeed, reversal sends \(b(A)\) to \(-b(A)\), so the exponential is even and has reverse norm one. The commutator identity \([b(A),\iota (v)]=\iota (Av)\) gives the displayed conjugation formula by the exponential series. Hence \(g_A(t)\) satisfies the three closed conditions above and belongs to the actual Spin group.
The tangent Lie algebra at \(1\) is exactly the image of \(b\). One inclusion is supplied by the curves \(g_A\). Conversely, let \(X\) be tangent at \(1\). Differentiating evenness, reverse norm one, and vector normalization gives \[X\text { even},\qquad \operatorname {rev}(X)=-X, \qquad [X,\iota (V)]\subseteq \iota (V).\] Write \([X,\iota (v)]=\iota (Av)\). Differentiating preservation of \(Q\) makes \(A\) skew-adjoint. Then \(X-b(A)\) is even and commutes with every vector, so it is scalar; reverse antisymmetry forces that real scalar to vanish. Therefore \[T_1\operatorname {Spin}(Q)=b\bigl (\mathfrak {so}(V,B_Q)\bigr ), \qquad d_1(\operatorname {spinVectorAction})\bigl (b(A)\bigr )=A.\] This is the genuine differential statement whose algebraic commutator precursor appears in Theorem [fcap-000R] and whose polar-dual coordinate formula is Theorem [fcap-001Z].
If \(\pi :\mathcal {C}\kern -2pt\ell (Q)\to \operatorname {End}_{\mathbb R}(S)\) is a finite-dimensional real Clifford module, continuity of the power series gives \[\pi (g_A(t))=\exp \bigl (t\pi (b(A))\bigr ), \qquad d\pi _1\bigl (b(A)\bigr )=\pi (b(A)).\] A complex Clifford module may be regarded here as a real module; this does not assert a separately constructed complex Lie-group structure.
[meinrenken2013clifford, Proposition 2.12, p. 40; Proposition 3.2, pp. 53--54] proves the normalized bivector realization and the Spin exponential/action identity. [lawson2016spin, I.2, Remark 2.1 and (2.6)--(2.7), pp. 13--14] independently give the ambient Clifford exponential and its conjugation derivative. The carrier completion and tangent converse above identify the exact vector-generated group used here; Lawson's ambient exponential formula alone does not supply that membership.
For the convention match, Meinrenken's bilinear form \(B_M\) satisfies
\(B_Q=2B_M\). If \((e_M^i)\) is \(B_M\)-dual to \((e_i)\), then the
\(B_Q\)-dual vectors are \(e_M^i/2\), and
\[b(A)=\frac 12\sum _i\beta _Q\left (Ae_i,\frac 12e_M^i\right )
=\frac 14\sum _i\beta _Q(Ae_i,e_M^i)
=\frac 14\sum _i(Ae_i)e_M^i.\]
The last equality uses \(\operatorname {tr}(A)=0\); it does not rescale the
half-commutator \(\beta _Q\). TauCeti proves the algebraic lift and
generator action at the pinned revision through
CliffordAlgebra.quadraticLift_lie_ι and the coordinate
formula CliffordAlgebra.soEquivQuadratic_eq_sum_bivector.
The same normalization governs the actual compact differential below.
For the standard positive form \(Q_n^+\), TauCeti equips the closed
range of Spin in Clifford units with a Lie-group structure. The
continuous multiplicative equivalence
TauCeti.CliffordAlgebra.realCliffordSpinContinuousMulEquivUnitsRange
identifies this range with the original vector-generated carrier.
Write \(\eta :\Lambda ^2\mathbb R^n\to \mathfrak {cl}^2(Q_n^+)\) for the
exterior-bivector realization and \(\kappa :\Lambda ^2\mathbb R^n\to
\mathfrak {so}(n)\) for the standard bivector Lie equivalence. In these
coordinates the differential of the actual projection \(q:\operatorname {Spin}(n)\to
SO(n)\) satisfies
\[(d_1q)_{\mathrm {coord}}\bigl (\eta (z)\bigr )=\kappa (z),
\qquad
b(A)=\eta \bigl (\kappa ^{-1}(A)\bigr ).\]
The first equality is
TauCeti.CliffordAlgebra.realCliffordSpinToSpecialOrthogonalCoordinateLieHom_eq_bivectorEquivSo.
Its proof differentiates conjugation by the Clifford exponential and
identifies the resulting action with the commutator above. Thus neither
an extra sign nor a factor of two is inserted in passing from the
algebraic lift to the group differential.
There is also an all-signature exponential criterion. For the
standard real form \(Q_{p,q}\),
CliffordAlgebra.forall_expUnit_smul_mem_realCliffordSpinGroup_iff_mem_quadraticLieSubalgebra
states, for an ambient Clifford element \(x\),
\[\bigl (\forall t\in \mathbb R,\ \exp (tx)\in \operatorname {Spin}(Q_{p,q})\bigr )
\quad \Longleftrightarrow \quad
x\in \mathfrak {cl}^2(Q_{p,q}).\]
Here the exponential is first formed as a Clifford unit and membership
is in the actual Spin carrier. This quantifies over every real \(t\); it
does not identify quadratic elements from a single exponential value.
The differential declaration uses the compact form \(Q_n^+\); the
criterion ranges over all standard real signatures. The argument above
continues to supply the assertion for an arbitrary nondegenerate \(Q\).
Example. A planar Spin curve records the half-angle [fcap-0038]AGENTDRAFTED
Example. A planar Spin curve records the half-angle [fcap-0038]AGENTDRAFTED
Let \(Q(e_1)=Q(e_2)=1\) with \(B_Q(e_1,e_2)=0\), and let \(J(e_1)=-e_2\), \(J(e_2)=e_1\). The normalization in Proposition [fcap-0037] gives \[b(J)=\frac 12e_1e_2, \qquad g(\theta )=\exp \left (\frac \theta 2e_1e_2\right ) =\cos \frac \theta 2+\sin \frac \theta 2e_1e_2.\] Since \((e_1e_2)^2=-1\), direct multiplication gives \[g(\theta )e_1g(\theta )^{-1} =\cos \theta \,e_1-\sin \theta \,e_2.\] Thus differentiating at zero gives \(J\) with the displayed sign, while \[g(2\pi )=-1,\qquad g(4\pi )=1.\] The Spin parameter therefore has twice the period of its vector action. This is the rank-two curve used in the compact-cover calculation below.
[meinrenken2013clifford, Example 3.3, p. 54] computes the same Clifford exponential and planar action. His convention has \(B_M(e_i,e_i)=1\), hence the same generator squares; the preceding polar-form translation fixes the coefficient \(1/2\).
Theorem. Lie-algebra representations integrate uniquely on compact Spin [fcap-003L]AGENTDRAFTED
Theorem. Lie-algebra representations integrate uniquely on compact Spin [fcap-003L]AGENTDRAFTED
Let \(n\geq 3\), let \(F=\mathbb R\) or \(\mathbb C\), and let \(S\) be a finite-dimensional \(F\)-vector space. Put \(G=\operatorname {Spin}(Q_n^+)\) for the compact positive-square group of Proposition [fcap-0039], and write \(b:\mathfrak {so}(n)\to T_1G\) for the quadratic lift of Proposition [fcap-0037]. Every real-linear Lie-algebra homomorphism \[r:\mathfrak {so}(n)\longrightarrow \mathfrak {gl}_F(S)\] has a unique smooth group representation \(R:G\to GL_F(S)\) satisfying \[dR_1(b(A))=r(A),\qquad R\bigl (\exp (t b(A))\bigr )=\exp (t r(A)).\] Here \(A\in \mathfrak {so}(n)\) and \(t\in \mathbb R\). When \(F=\mathbb C\), the target \(\mathfrak {gl}_{\mathbb C}(S)\) is regarded as a real Lie algebra: the group being represented is compact real Spin, and its operators on \(S\) are complex-linear.
[fulton2004representation, Section 8.3, Proposition 8.41 and Second Principle, pp. 118--119] proves integration by the graph-subgroup construction. The concrete Lie structure in Proposition [fcap-0037] and simple connectedness in Proposition [fcap-003A] supply its hypotheses for the selected Spin carrier.
Proof.
Proof.
Compose \(r\) with \(b^{-1}\) to obtain a Lie homomorphism \(\widetilde r:T_1G\to \mathfrak {gl}_F(S)\). Its graph \[\mathfrak j=\{(X,\widetilde r(X)):X\in T_1G\}\] is a real Lie subalgebra of \(T_1G\oplus \mathfrak {gl}_F(S)\). The Lie-subgroup theorem integrates it to a connected immersed subgroup \(J\subseteq G\times GL_F(S)\). Projection onto the first factor gives a homomorphism \(p:J\to G\) whose differential is an isomorphism.
Thus \(p\) is a local diffeomorphism. Its image is an open subgroup of connected \(G\), hence all of \(G\). Moreover, \(p\) is a covering: choose an identity neighborhood \(U\subseteq J\) on which \(p\) is a diffeomorphism onto \(V\subseteq G\). The inverse image of \(V\) is the disjoint union of the translates \(kU\), \(k\in \ker p\); every translate maps diffeomorphically to \(V\). Since \(J\) is connected and \(G\) is simply connected, this covering is an isomorphism. Projection onto the second factor after \(p^{-1}\) is the required \(R\).
A smooth homomorphism carries a one-parameter subgroup to the one-parameter subgroup with the differentiated generator. This gives the exponential identity above. If two homomorphisms have the stated differential, they therefore agree on the image of an exponential neighborhood of zero. An identity neighborhood generates every connected Lie group, so they agree on all of \(G\).
TauCeti's lieMap_injective proves this uniqueness
principle for smooth homomorphisms out of a preconnected finite-dimensional
real Lie group. It does not supply the existence construction above. The
restriction \(n\geq 3\) enters through simple connectedness; the circle
\(\operatorname {Spin}(2)\) does not have the same unrestricted integration property.
Proposition. The central sign determines descent to the special orthogonal group [fcap-003M]AGENTDRAFTED
Proposition. The central sign determines descent to the special orthogonal group [fcap-003M]AGENTDRAFTED
Keep the hypotheses and notation of Theorem [fcap-003L], and let \(q:G\to SO(n)\) be the vector action. The integrated representation \(R\) factors through a smooth representation \(\overline R\) of \(SO(n)\) precisely when \[R(-1)=\operatorname {Id}_S.\] Equivalently, let \(J\in \mathfrak {so}(n)\) send \(e_1\mapsto -e_2\), \(e_2\mapsto e_1\), and vanish on the remaining coordinate vectors. Then the descent condition is \[\exp \bigl (2\pi r(J)\bigr )=\operatorname {Id}_S.\]
Proof.
Proof.
The covering Proposition [fcap-0039] has kernel \(\{1,-1\}\). A factorization forces \(R(-1)=\overline R(1)=\operatorname {Id}_S\). Conversely, under that condition set \(\overline R(q(g))=R(g)\). Any two lifts differ by \(1\) or \(-1\), so the value is independent of the lift. Surjectivity of \(q\) proves both the homomorphism law and uniqueness of \(\overline R\). The differential of \(q\) is an isomorphism by Proposition [fcap-0037]; its local smooth inverse sections express \(\overline R\) locally as \(R\) composed with a smooth section. Hence the descended representation is smooth. Finally, Example [fcap-0038] gives \[\exp \bigl (2\pi b(J)\bigr )=-1,\] so exponential naturality identifies \(R(-1)\) with the displayed matrix exponential.
This criterion compares the integrated action with Clifford modules. Suppose \[f:\mathcal {C}\kern -2pt\ell ^0(Q_n^+)\longrightarrow \operatorname {End}_F(S)\] is a unital real-algebra homomorphism from the even Clifford algebra. Its restriction \(R_f(g)=f(g)\) takes Spin to invertible operators, with inverse \(f(g^{-1})\). Finite-dimensional linearity makes this restriction smooth. Since \(b(A)\) is even, the exponential power series stays inside \(\mathcal {C}\kern -2pt\ell ^0(Q_n^+)\) and gives \[R_f\bigl (\exp (t b(A))\bigr ) =\exp \bigl (t f(b(A))\bigr ).\] Since \(f\) preserves commutators, \(r(A)=f(b(A))\) is a Lie-algebra action. Consequently \(d(R_f)_1(b(A))=f(b(A))\). The uniqueness in Theorem [fcap-003L] identifies \(R_f\) with the integrated action for \(r(A)=f(b(A))\); it is an equality on the chosen module, not merely an unspecified representation equivalence.
Unitality gives \(R_f(-1)=-\operatorname {Id}_S\). Thus a nonzero such module does not descend to \(SO(n)\). This includes the complex spin and half-spin modules: they are restrictions of modules for the complexified even Clifford algebra, as described in [meinrenken2013clifford, Section 3.7.5, pp. 80--81]. No extension of a half-spin module to the full Clifford algebra is needed. The central scalar \(-1\) is fixed by the even-algebra sign comparison in Proposition [fcap-0039], so this obstruction is unchanged by the two Clifford sign conventions.
The same calculation shows why tensor constructions can descend. On \(S\otimes _F S\) the central element acts by \((-\operatorname {Id})\otimes (-\operatorname {Id})=\operatorname {Id}\); on \(\operatorname {End}_F(S)\) its conjugation action is also the identity. Both actions therefore factor through \(SO(n)\). Differentiating their defining group actions gives, respectively, \[\begin {aligned} A\cdot (s\otimes t)&=r(A)s\otimes t+s\otimes r(A)t,\\ A\cdot T&=r(A)T-Tr(A). \end {aligned}\] The tensor formula agrees with [fulton2004representation, Section 8.1, equation (8.12), p. 110]. Descent concerns the central action of the whole group, even though these differentiated formulas use only its Lie algebra.
For an action of the full real Clifford algebra, TauCeti's
AlgHom.lieMap_realCliffordSpinSmoothHom_eq
identifies its differentiated smooth restriction with the quadratic
Clifford action. The declaration uses the closed Spin range in Clifford
units and its Lie-algebra coordinates; the natural carrier equivalence
transports the action back to \(G\). Its input is a full-Clifford algebra
homomorphism into a finite-dimensional normed real algebra. It does not
state the even-module extension or the descent criterion proved here.
The actual orthogonal differential fixes its coordinates as well.
Let \(X\in T_1\operatorname {Spin}(n)\) and put \(A=d_1q(X)\), expressed as a
skew-symmetric matrix. With the normalized \(b\) from
Proposition [fcap-0037], the refined identity is
\[d(R_f)_1(X)=f\bigl (b(A)\bigr )
=f\bigl (\eta (\kappa ^{-1}(A))\bigr ).\]
AlgHom.unitsLieAlgebraLieEquiv_lieMap_realCliffordSpinSmoothHom_eq_bivectorExterior
proves this after the canonical identification of the target units Lie
algebra with its ambient algebra. Its \(A\) comes from the differential
of the actual Spin projection, so the formula has the normalization
already checked in Proposition [fcap-0037]. The input remains a homomorphism
from the full \(\mathcal {C}\kern -2pt\ell (Q_n^+)\) into a finite-dimensional normed real
algebra. It supplies the differential comparison for that restriction;
the integration, even-only and half-spin cases, and central-sign descent
argument retain their separate proofs above and in Theorem [fcap-003L].
Polarization and the exterior spinor model [fcap-001G]AGENTDRAFTED
Polarization and the exterior spinor model [fcap-001G]AGENTDRAFTED
A polarization turns Clifford generators into creation, contraction, and parity operators on an exterior algebra. The resulting Clifford action has two group restrictions and receives every orthogonal Lie action through the quadratic Clifford realization.
Write \(S=\bigwedge _K W\) for the exterior carrier and \(\rho :\mathcal {C}\kern -2pt\ell (Q)\to \operatorname {End}(S)\) for its Clifford action. Let \(\mathfrak g\) be an external Lie algebra with an orthogonal action \(\theta :\mathfrak g\to \mathfrak {so}(V,Q)\). The diagram records the induced Lie action at the top and the Pin and Spin restrictions of \(\rho \) below.
§ [ca-0001]
Definition. Polarization data and its carrier [chevalley1954algebraic, II.2.1--II.2.2, pp. 42--44] [fcap-001H]
L∃∀NAGENTDRAFTED
Definition. Polarization data and its carrier [chevalley1954algebraic, II.2.1--II.2.2, pp. 42--44] [fcap-001H]
L∃∀NAGENTDRAFTED
Let \(K\) be a commutative ring, let \(V\) be a \(K\)-module, and let \(Q\) be a quadratic form. Polarization data consists of isotropic submodules \(W,W'\subseteq V\), an orthogonal remainder \(L\), and a linear equivalence \[(W\oplus W')\oplus L\simeq V.\] The polar form identifies \(W'\) with \(W^*\); the pairing is separating in both variables. A coordinate \(\ell :L\to K\) is injective and satisfies \(\ell (z)^2=Q(z)\). Thus \(L\) is an orthogonal remainder equipped with an injective coordinate. Over a field it is at most one-dimensional; it vanishes in the classical even split model. The carrier of the exterior spinor model is \[S=\bigwedge _K W.\]
Chevalley treats complementary totally singular subspaces in the split, even-dimensional field case. Meinrenken uses the equivalent Lagrangian model \(V=F^*\oplus F\) [meinrenken2013clifford, Section 3.2.2, Proposition 3.5, pp. 56--57]. The packaged remainder and commutative-ring hypotheses are TauCeti's stated generalization.
Convention. Clifford generators and polarized operators [fcap-0027]AGENTDRAFTED
Convention. Clifford generators and polarized operators [fcap-0027]AGENTDRAFTED
Let \(Q\) be a quadratic form on a module \(V\) over a commutative ring \(K\). Write \[B_Q(u,v)=Q(u+v)-Q(u)-Q(v)\] for its unhalved polar form, and reserve \(\iota _Q:V\to \mathcal {C}\kern -2pt\ell (Q)\) for the canonical Clifford generator map. Then \[\iota _Q(u)\iota _Q(v)+\iota _Q(v)\iota _Q(u) =B_Q(u,v)1.\] If \(2\) is invertible, write \(b_Q=\tfrac 12B_Q\); the same relation is then \(\{\iota _Q(u),\iota _Q(v)\}=2b_Q(u,v)1\). No use of \(b_Q\) is made when division by two is unavailable.
For polarization data \(V\simeq (W\oplus W')\oplus L\) and
\(S=\bigwedge _K W\), the definitions are in Definition [fcap-001I]. Write
\(\varepsilon _x:S\to S\) for creation,
\(a_y=\iota _{\varphi _y}:S\to S\) for contraction,
\(\alpha :S\to S\) for parity, \(\lambda _z:S\to S\) for the orthogonal-line
action, and \(c(v):S\to S\) for the assembled Clifford operator.
In particular,
\[a_y\varepsilon _x+\varepsilon _xa_y
=B_Q(x,y)\operatorname {id}_S.\]
This is the normalization of
TauCeti.SpinPolarizationData.contract_wedge; the assembled
square \(c(v)^2=Q(v)\operatorname {id}_S\) is
TauCeti.SpinPolarizationData.cliffordOperator_sq. The
contracted notation \(\iota _y\) in Lemma [fcap-001J] and Example [fcap-001P] is a
legacy alias for \(a_y=\iota _{\varphi _y}\); it does not denote the generator
map \(\iota _Q\).
The source conventions translate as follows. Fulton--Harris use a symmetric bilinear form \(Q_{\mathrm {FH}}\) and write the anticommutator as \(2Q_{\mathrm {FH}}\); their contraction functional is also \(2Q_{\mathrm {FH}}(-,w')\) [fulton2004representation, Section 20.1, (20.1), Lemma 20.9 and (20.11), pp. 301, 304--305]. Meinrenken likewise starts from \(B\) with Clifford relation \(2B\) and, after choosing \(V=F^*\oplus F\), acts on \(\bigwedge F^*\) by creation from \(F^*\) and contraction from \(F\) [meinrenken2013clifford, Section 3.2.1--3.2.2, Proposition 3.5, pp. 55--57]. Thus \(Q_{\mathrm {FH}}=B=b_Q\) whenever \(b_Q\) exists. Goodman--Wallach instead name the anticommutator form \(\beta \); under their identification \(W_{\mathrm {GW}}^*=W\) and \(W_{\mathrm {GW}}=W'\), one has \(\beta =B_Q\) [goodman2009symmetry, Definition 6.1.1 and Theorem 6.1.3, proof, pp. 302, 304--305]. The formulas agree after these substitutions; the different letters do not signal different Clifford actions.
Definition. The three polarized Clifford operators [fcap-001I]
L∃∀NAGENTDRAFTED
Definition. The three polarized Clifford operators [fcap-001I]
L∃∀NAGENTDRAFTED
Let \(P\) be polarization data as in Definition [fcap-001H], over a commutative ring \(K\), and set \(S=\bigwedge _K W\). For \(x\in W\), creation is exterior multiplication \[\varepsilon _x(s)=x\wedge s.\] For \(y\in W'\), let \(\varphi _y(x)=B_Q(x,y)\). Annihilation is contraction against this functional, \[a_y(s)=\iota _{\varphi _y}(s).\] If \(z\in L\), its operator is \[\lambda _z=\ell (z)\,\alpha ,\] where \(\alpha (s)=(-1)^r s\) for homogeneous \(s\in \bigwedge ^r W\). The Clifford operator attached to the decomposed vector \(v=x+y+z\) is therefore \[c(v)=\varepsilon _x+a_y+\lambda _z.\]
These symbols separate three maps that sources often denote similarly. The canonical generator map is \(\iota _Q:V\to \mathcal {C}\kern -2pt\ell (Q)\); the representation then satisfies \[\rho (\iota _Q(x))=\varepsilon _x,\qquad \rho (\iota _Q(y))=a_y,\qquad \rho (\iota _Q(z))=\lambda _z.\] Thus contraction is an operator on \(S\), not another use of the symbol for the Clifford generator. The normalization and source dictionary are fixed in Convention [fcap-0027].
Chevalley obtains creation and contraction from left multiplication on a minimal ideal: one totally singular summand acts by exterior multiplication, and the complementary summand by antiderivations [chevalley1954algebraic, II.2.1--II.2.2, pp. 42--44]. Meinrenken's Lagrangian-complement construction gives the same pair as \(\varepsilon (\mu )+\iota (v)\) [meinrenken2013clifford, Section 3.2.2, Proposition 3.5, p. 57]. Fulton--Harris independently writes the two actions as exterior multiplication and derivation, with the derivation paired by their anticommutator form [fulton2004representation, Section 20.1, Lemma 20.9 and (20.11), pp. 304--305]. Fulton--Harris and Goodman--Wallach extend the model in odd dimension by sending a normalized orthogonal generator to parity [fulton2004representation, Lemma 20.16, p. 306], and [goodman2009symmetry, Theorem 6.1.3, proof, p. 305]. TauCeti packages this last step as the supplied coordinate \(\ell :L\to K\), so that every \(z\in L\) acts by \(\ell (z)\alpha \). Chevalley's cited result is the field case of maximal index; Meinrenken assumes a field of characteristic different from two, a split form, and a chosen Lagrangian complement; Fulton--Harris and Goodman--Wallach work with finite-dimensional nondegenerate complex spaces and chosen maximal isotropics. Once \(P\) is supplied, the four displayed TauCeti operators require no additional field, finite-dimensionality, nondegeneracy, or division-by-two hypothesis.
Lemma. The polarized Clifford relation [meinrenken2013clifford, Section 3.2.1, pp. 54--55] [fcap-001J]
L∃∀NAGENTDRAFTED
Lemma. The polarized Clifford relation [meinrenken2013clifford, Section 3.2.1, pp. 54--55] [fcap-001J]
L∃∀NAGENTDRAFTED
Creation and contraction satisfy \[\iota _y\varepsilon _x+\varepsilon _x\iota _y =B_Q(x,y)\operatorname {id}_S.\] Creation and contraction each square to zero. Parity anticommutes with both, while \(\lambda _z^2=Q(z)\operatorname {id}_S\). Consequently the operator \(c(v)\) assembled from the three polarization coordinates obeys \[c(v)^2=Q(v)\operatorname {id}_S.\] This is the quadratic form of the usual polarized anticommutation relation \(c(v)c(w)+c(w)c(v)=B_Q(v,w)\). Meinrenken states the latter as the defining condition for a Clifford module.
Theorem. The exterior Clifford action [meinrenken2013clifford, Section 3.2.2, Proposition 3.5, p. 57] [fcap-001K]
L∃∀NAGENTDRAFTED
Theorem. The exterior Clifford action [meinrenken2013clifford, Section 3.2.2, Proposition 3.5, p. 57] [fcap-001K]
L∃∀NAGENTDRAFTED
The square relation of Lemma [fcap-001J] extends uniquely to an algebra
homomorphism
\[\rho :\mathcal {C}\kern -2pt\ell (Q)\longrightarrow \operatorname {End}_K(S).\]
On the three summands it is determined by
\[\rho (\iota (x))s=x\wedge s,\qquad
\rho (\iota (y))s=\iota _y(s),\qquad
\rho (\iota (z))s=\ell (z)\alpha (s).\]
The corresponding formalized equations are
TauCeti.spinAction_ι_wedge,
TauCeti.spinAction_ι_contract, and
TauCeti.spinAction_ι_lineOperator.
Chevalley's split even-dimensional model has no remainder term; the third
formula is TauCeti's odd-line extension of that construction.
Theorem. Creation and contraction generate all endomorphisms [meinrenken2013clifford, Section 3.2.4, Theorem 3.3, pp. 59--60] [fcap-001L]
L∃∀NAGENTDRAFTED
Theorem. Creation and contraction generate all endomorphisms [meinrenken2013clifford, Section 3.2.4, Theorem 3.3, pp. 59--60] [fcap-001L]
L∃∀NAGENTDRAFTED
Assume that \(W\) is finite and free over the commutative ring \(K\). The subalgebra of \(\operatorname {End}_K(\bigwedge W)\) generated by all creation operators and all contractions is the whole endomorphism algebra. Since the polar pairing identifies \(W'\) with \(W^*\), these generators lie in the image of the exterior Clifford action. Hence \[\rho :\mathcal {C}\kern -2pt\ell (Q)\twoheadrightarrow \operatorname {End}_K(\bigwedge W)\] is surjective.
Meinrenken proves generation first in rank one by four matrix units and then by tensor decomposition. Over a split field he combines surjectivity with a dimension calculation to obtain an isomorphism and irreducibility. TauCeti formalizes the generation and surjectivity statements over a finite free module. This card does not claim that \(S\) is irreducible, or that \(\rho \) is injective.
Definition. The Spin and Pin representations [meinrenken2013clifford, Section 3.2.1, pp. 55--56] [fcap-001M]
Definition. The Spin and Pin representations [meinrenken2013clifford, Section 3.2.1, pp. 55--56] [fcap-001M]
The groups \(\operatorname {Spin}(Q)\) and \(\operatorname {Pin}(Q)\) consist of units in the Clifford algebra. Restricting the action \(\rho \) of Theorem [fcap-001K] along these two inclusions gives representations on the same exterior carrier: \[\operatorname {spinRep}:\operatorname {Spin}(Q)\longrightarrow \operatorname {Aut}_K(S), \qquad \operatorname {pinRep}:\operatorname {Pin}(Q)\longrightarrow \operatorname {Aut}_K(S).\] Meinrenken calls the restriction of a Clifford module to the Clifford group the spin representation. The definitions here require only the commutative ring, module, quadratic form, and polarization data already used for \(\rho \); no nondegeneracy or finite-dimensionality is added.
Lemma. The restricted actions are the Clifford action [meinrenken2013clifford, Section 3.2.1, pp. 55--56] [fcap-001N]
L∃∀NAGENTDRAFTED
Lemma. The restricted actions are the Clifford action [meinrenken2013clifford, Section 3.2.1, pp. 55--56] [fcap-001N]
L∃∀NAGENTDRAFTED
For every \(g\in \operatorname {Spin}(Q)\) and \(h\in \operatorname {Pin}(Q)\), the two representations act through their underlying Clifford units: \[\operatorname {spinRep}(g)=\rho (g),\qquad \operatorname {pinRep}(h)=\rho (h).\] Thus the group actions introduce no new formula on \(S\); they are the same Clifford action with a smaller domain. In particular, any equation proved for the action of the underlying Clifford element applies to its Spin or Pin restriction.
Example. Rank one: matrix units and occupation [fcap-001P]AGENTDRAFTED
Example. Rank one: matrix units and occupation [fcap-001P]AGENTDRAFTED
Let \(K\) be a commutative ring in which \(2\) is invertible, and consider polarization data for which \(W=Ke\) is free of rank one. Let \(e'\in W'\) be the dual vector, so \(B_Q(e,e')=1\). Following Convention [fcap-0027], put \(c=\varepsilon _e\) and \(a=a_{e'}=\iota _{e'}\); the last expression uses the legacy contraction notation. In the ordered basis \((1,e)\) of \(S=\bigwedge W\), \[c=\begin {pmatrix}0&0\\1&0\end {pmatrix}, \qquad a=\begin {pmatrix}0&1\\0&0\end {pmatrix}.\] Thus \(c^2=a^2=0\), \(ca+ac=I_2\), and \[ac=\begin {pmatrix}1&0\\0&0\end {pmatrix}=E_{00}, \quad a=E_{01},\quad c=E_{10},\quad ca=\begin {pmatrix}0&0\\0&1\end {pmatrix}=E_{11}.\] These are all four matrix units of \(\operatorname {End}_K(S)\).
The product \[N:=ca\] is the one-mode number operator: \(N(1)=0\) and \(N(e)=e\). Centering its two eigenvalues gives \[H:=N-\tfrac 12 I_2 =\begin {pmatrix}-\tfrac 12&0\\0&\tfrac 12\end {pmatrix}.\] In several modes, \(N_i=c_i a_i\) tests whether the \(i\)-th exterior coordinate is occupied, and \(H_i=N_i-\frac 12\) is the diagonal operator used in Theorem [fcap-0025].
Over his characteristic-not-two field, Meinrenken supplies the general creation--contraction exterior model [meinrenken2013clifford, Proposition 3.5, p. 57] and the normal-ordered isomorphism onto the full endomorphism space [meinrenken2013clifford, Remark 3.5 and (3.6), p. 60]. The four matrices above are the direct rank-one specialization made here. The centered occupation operator independently appears in the Fulton--Harris calculation [fulton2004representation, Proposition 20.15, proof, pp. 305--306].
The occupation identity for every exterior basis vector is
TauCeti.SpinPolarizationData.wedge_contract_dualVector_basis,
and the general finite-free statement that the Clifford action reaches every
endomorphism is
TauCeti.spinAction_surjective. The displayed \(2\times 2\)
matrices and their labels \(E_{rs}\) are a basis calculation, not separately
named formal declarations.
Theorem. Matrix units give the even-dimensional structure theorem [fcap-002V]AGENTDRAFTED
Theorem. Matrix units give the even-dimensional structure theorem [fcap-002V]AGENTDRAFTED
Let \(K\) be a field of characteristic different from \(2\), and let \(V\) be a finite-dimensional split quadratic space with a chosen polarization \(V=W\oplus W'\) into complementary isotropic subspaces. Put \(\dim _KW=\ell \), choose polar-dual bases \(e_i\in W\) and \(e_i'\in W'\) with \(B_Q(e_i,e_j')=\delta _{ij}\), and set \(S=\bigwedge W\). In the notation of Convention [fcap-0027], write \[c_i=\varepsilon _{e_i},\qquad a_i=a_{e_i'},\qquad N_i=c_i a_i,\qquad P_0=\prod _i(1-N_i)=\prod _i a_i c_i.\] The commuting idempotents \(N_i\) record occupation, so \(P_0\) is the projection onto the vacuum line \(K1\). For increasing subsets \(I=\{i_1<\cdots <i_p\}\) and \(J=\{j_1<\cdots <j_q\}\), put \[c_I=c_{i_1}\cdots c_{i_p},\qquad a_J=a_{j_q}\cdots a_{j_1},\qquad F_{I,J}=c_IP_0a_J.\] The reversed contraction order is essential. If \(e_K\) denotes the increasing exterior basis vector, then \[F_{I,J}(e_K)=\delta _{J,K}e_I,\qquad F_{I,J}F_{K,L}=\delta _{J,K}F_{I,L}.\] Indeed, \(a_J(e_J)=1\). A missing index makes the contraction zero, while a properly larger \(K\) leaves positive exterior degree and is killed by \(P_0\). Finally \(c_I(1)=e_I\). Thus the \(F_{I,J}\) are all matrix units in the image of the Clifford action. This is the multimode extension of the rank-one calculation in Example [fcap-001P].
The matrix units prove surjectivity, and the dimension equality
\[\dim _K\mathcal {C}\kern -2pt\ell (Q)=2^{2\ell }=(2^\ell )^2
=\dim _K\operatorname {End}_K(S)\]
then proves injectivity. Hence
\[\mathcal {C}\kern -2pt\ell (Q)\simeq \operatorname {End}_K(S).\]
This full equivalence is formalized by
TauCeti.spinAction_bijective and
TauCeti.SpinPolarizationData.cliffordEquivEnd. The
displayed multi-index matrix units are the basis calculation supplied here,
not a separately named declaration.
Every factor in \(P_0\) is even, so the Clifford parity of \(F_{I,J}\) is
\(|I|+|J|\) modulo \(2\). The even matrix units are therefore exactly those
with \(|I|\equiv |J|\pmod {2}\); they span the two diagonal blocks and give
\[\mathcal {C}\kern -2pt\ell (Q)^0\simeq
\operatorname {End}_K(S^+)\oplus \operatorname {End}_K(S^-),\qquad
S^+=\bigwedge ^{\mathrm {even}}W,\quad
S^-=\bigwedge ^{\mathrm {odd}}W.\]
The exact formal block equivalence is
TauCeti.SpinPolarizationData.evenCliffordEquivProdEnd.
If \(\ell \geq 1\), each block has size \(2^{\ell -1}\) and each parity summand
is simple for its full endomorphism block
TauCeti.SpinPolarizationData.evenCliffordEquivProdMatrix.
For \(\ell =0\), the full action still identifies \(K\) with
\(\operatorname {End}_K(K)\), but \(S^-=0\) and is not called a simple
summand.
At the group level, the block calculation alone does not prove
irreducibility after restriction to \(\operatorname {Spin}(Q)\). When \(K\) is additionally
separably closed and \(\ell \geq 1\), the formal Spin-spanning argument gives
the two irreducible half-spin representations
TauCeti.isIrreducible_spinPlusSubrep
TauCeti.isIrreducible_spinMinusSubrep.
This is stronger input than the occupation weights of Theorem [fcap-0025].
[fulton2004representation, Lemma 20.9 and (20.13), pp. 304--305] derive the full complex action and its two exterior-parity blocks; their bilinear form is the half-polar form \(b_Q\), so their contraction coefficient \(2Q_{\mathrm {FH}}\) is our \(B_Q\).
[meinrenken2013clifford, Section 3.2.4, Theorem 3.3 and (3.5)--(3.6), pp. 59--60] give the split action as a superalgebra isomorphism and prove it by the rank-one tensor calculation; their creation space \(F^*\) is our \(W\) and their bilinear form is \(b_Q\).
[goodman2009symmetry, Theorem 6.1.3, proof, pp. 304--305] independently obtain the complex creation--contraction carrier; their creation space \(W_{\mathrm {GW}}^*\) is our \(W\), and their form \(\beta \) is our unhalved \(B_Q\). The formula \(F_{I,J}=c_IP_0a_J\) synthesizes these arguments in the fixed FCAP order rather than quoting one source verbatim.
Proposition. An odd spinor action selects one Clifford summand [fcap-002W]AGENTDRAFTED
Proposition. An odd spinor action selects one Clifford summand [fcap-002W]AGENTDRAFTED
Work over \(\mathbb C\) with \(V=W\oplus W'\oplus \mathbb C z\), where \(W,W'\) are polar-dual isotropic spaces of dimension \(\ell \), \(z\) is orthogonal to them, and \(Q(z)=1\). On \(S=\bigwedge W\), the two Clifford actions agree on \(W\oplus W'\) and differ on the last generator: \[\rho _+(\iota _Q(z))=\alpha ,\qquad \rho _-(\iota _Q(z))=-\alpha ,\] where \(\alpha \) is exterior parity. For polar-dual bases, normalize the hyperbolic chirality element by \[\Gamma =\prod _{i=1}^{\ell } \bigl (1-2\iota _Q(e_i)\iota _Q(e_i')\bigr ).\] The even-dimensional action sends \(\Gamma \) to \(\prod _i(1-2N_i)=\alpha \). Moreover \(\Gamma ^2=1\), and \(\Gamma \) anticommutes with every hyperbolic vector. Consequently \[\chi =\Gamma \iota _Q(z),\qquad \chi ^2=1\] is central in \(\mathcal {C}\kern -2pt\ell (Q)\). The complementary central idempotents \[p_+=\frac {1+\chi }{2},\qquad p_-=\frac {1-\chi }{2}\] satisfy \[\rho _+(p_+)=1,\quad \rho _+(p_-)=0,\qquad \rho _-(p_+)=0,\quad \rho _-(p_-)=1.\] Thus each odd action has a visible nonzero kernel.
The central idempotents also identify the whole algebra, rather than only
showing a dimension mismatch. Given
\(A\in \operatorname {End}_{\mathbb C}(S)\), the preceding theorem supplies a
hyperbolic Clifford element \(a\) with common image \(A\). Therefore the joint
map obeys
\[(\rho _+,\rho _-)(p_+a)=(A,0),\qquad
(\rho _+,\rho _-)(p_-a)=(0,A).\]
It is surjective. Since
\[\dim _{\mathbb C}\mathcal {C}\kern -2pt\ell (Q)=2^{2\ell +1}
=2\dim _{\mathbb C}\operatorname {End}_{\mathbb C}(S),\]
it is an isomorphism
\[\mathcal {C}\kern -2pt\ell (Q)\simeq
\operatorname {End}_{\mathbb C}(S)\oplus
\operatorname {End}_{\mathbb C}(S).\]
The corresponding abstract two-block existence theorem is
CliffordAlgebra.nonempty_algEquiv_matrix_prod_of_finrank_eq_two_mul_add_one.
The explicit joint-map proof determines how the two actions select its
summands.
The restrictions \(\rho _+|_{\mathcal {C}\kern -2pt\ell (Q)^0}\) and
\(\rho _-|_{\mathcal {C}\kern -2pt\ell (Q)^0}\) are parity-conjugate. When \(\ell \geq 1\) they are
unequal, as the Spin element below shows; for \(\ell =0\) both are the same
scalar action. For every even Clifford word, the number of hyperbolic factors
has the same parity as the number of \(z\)-factors. Conjugation by \(\alpha \)
contributes exactly that sign, so
\[\rho _-(x)=\alpha \rho _+(x)\alpha ^{-1}
\qquad (x\in \mathcal {C}\kern -2pt\ell (Q)^0).\]
If \(\rho _+(x)=0\), conjugacy makes both coordinates of the joint isomorphism
zero, hence \(x=0\). The even source and target have the same dimension, so
either restriction is an isomorphism
\[\mathcal {C}\kern -2pt\ell (Q)^0\simeq \operatorname {End}_{\mathbb C}(S).\]
This faithful range is formalized by
TauCeti.evenSpinAction_surjective and
TauCeti.SpinPolarizationData.evenCliffordEquivEnd.
When \(\ell \geq 1\), exterior parity is not a decomposition into invariant
odd-dimensional Spin modules. Fix \(i\), put \(u=e_i+e_i'\), and note
\(Q(u)=Q(z)=1\). The even product
\[g=\iota _Q(z)\iota _Q(u)\in \operatorname {Spin}(Q)\]
belongs to the actual Spin carrier by the norm-one pair criterion
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
Its plus action is \(\alpha (c_i+a_i)\) and satisfies
\[1\longmapsto -e_i,\qquad e_i\longmapsto 1.\]
Its minus action is the negative of this operator. Thus the two even
restrictions are unequal, and this actual Spin element exchanges even and
odd exterior degree. For \(\ell =0\), the carrier \(S\) is one-dimensional and
\(S^-=0\); no two-summand parity claim is made.
[fulton2004representation, Lemma 20.16 and (20.18), p. 306] give the odd complex product algebra and the faithful even restriction. Their second full-Clifford module is written on \(\bigwedge W'\), rather than as a second sign on the same carrier.
[goodman2009symmetry, Theorem 6.1.3, proof, pp. 304--305] construct the exterior carrier. [goodman2009symmetry, Lemma 6.1.4(3), p. 306] put the two normalized odd-vector signs on this common carrier. This supplies the common-carrier translation used above.
[meinrenken2013clifford, Section 3.2.4, (3.5), p. 60] supplies the normalized chirality product on the hyperbolic block. His Theorem 3.3 is an even split theorem, not an odd product theorem. The two-idempotent conclusion here is restricted to the split complex setting; an odd Clifford center over a general real field need not split.
Theorem. Exterior pairings determine compact spinor reality [fcap-0041]AGENTDRAFTED
Theorem. Exterior pairings determine compact spinor reality [fcap-0041]AGENTDRAFTED
Let \(W=\mathbb C^m\), \(m\geq 1\), with ordered basis \(e_1,\ldots ,e_m\), and use the exterior action on \(S=\bigwedge W\) from Theorem [fcap-002V]. Write \([u]_{\mathrm {top}}\) for the coefficient of \(e_1\wedge \cdots \wedge e_m\), and let \(r\) reverse exterior products: \(r|_{\wedge ^kW}=(-1)^{k(k-1)/2}\). Then \[B(s,t)=[r(s)\wedge t]_{\mathrm {top}},\qquad B(t,s)=\epsilon _e B(s,t),\qquad \epsilon _e=(-1)^{m(m-1)/2}\] defines a nondegenerate complex bilinear Spin-invariant form in dimension \(2m\). It pairs complementary degrees. Hence for even \(m\) it restricts nondegenerately to each half-spin module; for odd \(m\) it pairs the two halves perfectly and vanishes on either half alone. In dimension \(2m+1\), use the odd action Proposition [fcap-002W] and the adjusted form \[B_o(s,t)=B(\alpha ^m s,t),\qquad B_o(t,s)=\epsilon _o B_o(s,t),\qquad \epsilon _o=(-1)^{m(m+1)/2},\] where \(\alpha |_{\wedge ^kW}=(-1)^k\). This form is again nondegenerate and Spin-invariant.
In the exterior basis the matrix of \(B\) has one entry \(\pm 1\)
in each row and column, pairing an index set with its complement; this
proves nondegeneracy. The underlying perfect wedge pairing has the formal
counterpart
exteriorPower.instIsPerfPairWedgePairing,
for complementary exterior powers of a finite free module over a
commutative ring with a chosen top-degree trivialization. Reversal supplies
the additional signs here. For degrees \(k\) and \(m-k\), commuting the
two wedge factors and comparing their reversal signs gives
\(\epsilon _e\). Also
\(B(\alpha s,t)=(-1)^mB(s,\alpha t)\), proving the stated odd flip sign.
Every creation and contraction operator is self-adjoint for \(B\): \[B(c_i s,t)=B(s,c_i t),\qquad B(a_i s,t)=B(s,a_i t).\] For creation, \(r(e_i\wedge s)=r(s)\wedge e_i\). For contraction on degree \(k\), \(r(a_i s)=(-1)^{k-1}a_i r(s)\). Apply the contraction derivation rule to \(r(s)\wedge t=0\) in degree \(m+1\); its two terms give the second identity. All other degree combinations vanish on both sides. Thus \(B(\rho (x)s,t)=B(s,\rho (\operatorname {rev}x)t)\). The reverse-norm-one condition in Remark [fcap-0028] proves invariance under the actual Spin group. For \(B_o\), every hyperbolic vector has adjoint sign \((-1)^m\), because it anticommutes with \(\alpha \); the extra generator \(\alpha \) has the same sign. These signs cancel on even words, giving the same reversion identity and Spin invariance.
These bilinear forms also determine conjugate-linear structures for the compact real form \(\operatorname {Spin}(n,0)\), where \(n=2m\) or \(2m+1\). Give \(S\) the positive Hermitian form \(H(s,t)=\overline {s}^{\,T}t\) in the exterior basis, conjugate-linear in its first argument. The operators \(c_i+a_i\), \(i(c_i-a_i)\), and, in odd dimension, \(\alpha \), are self-adjoint, square to \(1\), and anticommute pairwise. They realize the positive real Clifford generators. Consequently reversion is Hermitian adjunction on this real algebra, and \(H\) is Spin-invariant.
Let \(M\) be the real signed permutation matrix of \(B\) or \(B_o\), and let \(\epsilon \) be its flip sign. Then \[J(s)=M^T\overline {s},\qquad H(Js,t)=s^TMt,\qquad J^2=\epsilon \,1.\] Indeed, \(M^T=\epsilon M\) and \(MM^T=1\). Invariance of both forms and nondegeneracy of \(H\) imply that \(J\) commutes with compact Spin. Writing \(\mathcal B\) for the chosen bilinear form, the comparison is the following commuting triangle of complex linear maps:
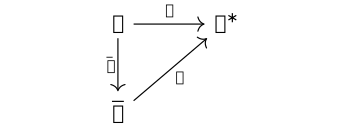
For \(\epsilon =1\), \(J\) is a real structure as in
Example [fcap-003W], and its fixed vectors form a real Spin module whose
complexification is \(S\)
Representation.IsRealStructure.isRealForm. Explicitly,
\[s=\frac {s+Js}{2}+i\frac {s-Js}{2i},\]
with both displayed components fixed by \(J\). For \(\epsilon =-1\),
\(J\) is a quaternionic structure: a conjugate-linear equivariant
map squaring to \(-1\)
Representation.IsQuaternionicStructure.
It has no nonzero fixed vector; together with multiplication by \(i\)
it gives the quaternion relations on the underlying real space.
To apply this to irreducible compact spinors, the restriction to Spin needs justification. Every even monomial in an orthonormal positive real Clifford basis has reverse norm one and lies in Spin. Such monomials span the real even algebra, hence their complex span is the complex even algebra. Therefore the block descriptions in Theorem [fcap-002V] and Proposition [fcap-002W] give irreducible compact half-spin modules in even dimension and an irreducible compact spin module in odd dimension. The even-dimensional halves are inequivalent because their two matrix blocks have different central supports.
In even dimension \(n=2m\), \(J\) preserves each half when \(m\) is
even and exchanges them when \(m\) is odd. In the latter case no
equivariant conjugate-linear bijection of one half to itself can exist:
composing it with \(J\) would give a
complex linear equivalence between the inequivalent halves. Thus the
compact types follow directly from the two flip signs:
\[\begin {array}{c|c}
n\bmod 8&\text {type of an irreducible complex spinor}\\\hline
0,1,7&\text {real}\\
3,4,5&\text {quaternionic}\\
2,6&\text {two conjugate, inequivalent half-spin modules}
\end {array}\]
In the even rows the statement applies to each half-spin module.
The general passage from an invariant nondegenerate complex bilinear
form, symmetric or alternating, and a supplied positive definite
invariant Hermitian form to a real or quaternionic structure is
formalized, for finite-dimensional
irreducible complex representations, by
Representation.exists_isRealStructure_of_isInvariantForm_of_isInvariantSesqForm
and
Representation.exists_isQuaternionicStructure_of_isInvariantForm_of_isInvariantSesqForm.
The explicit \(M\), odd adjustment, and compact residue calculation
are the exterior-basis proof above.
The reversal pairing and its covariance are [meinrenken2013clifford, Section 3.4, Definition 3.6, Example 3.5, and Proposition 3.14, pp. 66--67]. The compact reality classification agrees with [lawson2016spin, Chapter I, items 5.12--5.16, pp. 35--37]. Their negative-square Clifford convention is translated in Proposition [fcap-0042]. The positive Hermitian argument here is specific to the compact real form; it does not assign the same types to other signatures.
Definition [ca-000J]Definition [ca-0012]
Proposition. Real matrix blocks control Spin module complexification [fcap-0042]AGENTDRAFTED
Proposition. Real matrix blocks control Spin module complexification [fcap-0042]AGENTDRAFTED
Let \(A=M_d(D)\), where \(d\geq 1\) and \(D\in \{\mathbb R,\mathbb C,\mathbb H\}\), regarded as a real algebra. Its unique irreducible real left module is \(U=D^d\), with commutant \(D^{\mathrm {op}}\) acting by right multiplication. Its complexification has the following form: \[\begin {array}{c|c|c|c} D&A\otimes _{\mathbb R}\mathbb C&U\otimes _{\mathbb R}\mathbb C &\dim _{\mathbb C}S\\\hline \mathbb R&M_d(\mathbb C)&S&d\\ \mathbb C&M_d(\mathbb C)\oplus M_d(\mathbb C)&S\oplus \overline S&d\\ \mathbb H&M_{2d}(\mathbb C)&S\oplus S&2d \end {array}\] In the complex row, the two summands have different central supports; in the quaternionic row, they are isomorphic. For a product of real matrix algebras, first select one simple block. These statements apply to irreducible real Spin modules obtained from even Clifford algebras because the actual Spin group spans the even algebra.
For the matrix-module assertion, the idempotents \(E_{ii}\) split
any module into its coordinate corners, and \(E_{ij}\) identify the
corners with one another. A simple module therefore has a simple
\(D\)-module in its first corner, which is one-dimensional over the
division algebra \(D\); this gives \(D^d\). For an endomorphism commuting
with the full algebra, the matrix units make all coordinate maps the
same. Commutation with the \(D\)-valued diagonal entries makes this
common map \(f\) left \(D\)-linear, so \(f(x)=xf(1)\). It is therefore
right multiplication by a single element on every coordinate.
With \(R_a(u)=ua\), composition is
\(R_aR_b=R_{ba}\), explaining the opposite algebra. Conjugation
identifies \(D^{\mathrm {op}}\) with \(D\) when only its real algebra
type is recorded. This is the real matrix-module classification of
[lawson2016spin, Chapter I, Theorem 5.6, pp. 31--32].
The matrix-corner reconstruction has the general formal counterpart
ModuleCat.matrixEquivalence, an equivalence between
modules over a ring and modules over its matrix ring with a finite
nonempty index type. The three real types and their commutants are
the specializations calculated here.
The real row complexifies by entrywise scalar extension;
conjugation is the resulting real structure. For the other
rows, give \(U\) the complex structure \(u\mapsto ui\). The
complexification of an underlying real complex space decomposes as
\(S\oplus \overline S\), the two eigenspaces of this operator after
scalar extension. For \(D=\mathbb C\), the central element \(i1\)
acts as \(i\) on one summand and \(-i\) on the other. They are therefore
inequivalent. For \(D=\mathbb H\), right multiplication
\(J(u)=uj\) commutes with the left algebra action and obeys
\(J(uz)=J(u)\overline z\) and \(J^2=-1\). Thus it identifies
\(\overline S\) with \(S\). The quaternion matrix embedding
Quaternion.toComplexMatrix_apply
sends \(1,i,j,k\) to a complex basis of \(M_2(\mathbb C)\).
Scalar extension consequently gives
\(\mathbb H\otimes _{\mathbb R}\mathbb C\simeq M_2(\mathbb C)\)
and then the displayed matrix algebra for general \(d\). Its action
on \(S\) is the defining simple module of complex dimension \(2d\).
Here is the promised group-to-algebra bridge in every
nondegenerate real signature. Choose orthogonal Clifford generators
\(e_i\) with \(e_i^2=\varepsilon _i\in \{1,-1\}\).
The real span \(L\) of Spin is a unital subalgebra, since products
of linear combinations expand into linear combinations of group
products. For \(i\ne j\) with \(\varepsilon _i\varepsilon _j=1\),
\(e_ie_j\) itself lies in Spin by Remark [fcap-0028]. For opposite signs put
\[v=\frac {5\varepsilon _i}{3}e_i+\frac 43e_j,\qquad
Q(v)=\varepsilon _i,\qquad
g=e_iv=\frac 53+\frac 43e_ie_j\in \operatorname {Spin}(Q).\]
The last inclusion again uses \(Q(e_i)Q(v)=1\), hence the actual
norm-one Lipschitz carrier. Therefore
\(e_ie_j=\frac 34(g-\frac 53\,1)\in L\).
All bivectors lie in \(L\); their products and \(1\) span the even
Clifford algebra by its orthogonal monomial basis. Thus
\[\operatorname {span}_{\mathbb R}\operatorname {Spin}(p,q)=\mathcal {C}\kern -2pt\ell ^+(p,q).\]
It follows that real invariant subspaces and commuting endomorphisms
for Spin are exactly those for the even algebra. TauCeti's
CliffordAlgebra.span_spinGroup_eq_even_of_isSquare
proves the spanning conclusion under a square-normalization hypothesis
for every pair of nonisotropic vectors. That hypothesis holds for a
definite real form, but fails for opposite-sign pairs. The displayed
rational combination supplies the indefinite case separately.
For the compact positive form with \(n\geq 1\), the generators \(e_ie_n\), \(1\leq i<n\), square to \(-1\), anticommute, and generate the even algebra. Equality of dimensions gives \[\mathcal {C}\kern -2pt\ell ^+(n,0)\simeq \mathcal {C}\kern -2pt\ell (0,n-1).\] Combining the real classification Remark [fcap-0016] with the three rows above recovers the compact module types of Theorem [fcap-0041]. Lawson--Michelsohn write \(\mathcal {C}\kern -2pt\ell _n\) for our \(\mathcal {C}\kern -2pt\ell (0,n)\); their even-algebra identification and module table use this convention [lawson2016spin, Chapter I, (5.4)--(5.5) and Theorem 5.8, Table III, pp. 32--33]. Their compact Spin-spanning argument appears in Proposition 5.12, p. 36; the opposite-sign calculation above extends the linear-span argument to indefinite forms.
Signature still changes the real module type: \[\begin {aligned} \mathcal {C}\kern -2pt\ell ^+(2,2)&\simeq M_2(\mathbb R)\oplus M_2(\mathbb R),\\ \mathcal {C}\kern -2pt\ell ^+(4,0)&\simeq \mathbb H\oplus \mathbb H. \end {aligned}\] The split case gives real two-dimensional half-spin modules. The compact case gives quaternionic complex two-dimensional halves, each with real dimension four. The Lorentz even algebra \(M_2(\mathbb C)\) in Example [fcap-002L] has a real four-dimensional simple module; its complexification is the pair of inequivalent complex two-dimensional Weyl modules. Thus the compact Hermitian comparison cannot simply be reused for noncompact signatures. In all cases the scalar \(-1\in \operatorname {Spin}\) acts as \(-\operatorname {id}\), retaining the descent obstruction of Proposition [fcap-003M].
Theorem. Occupation signs split the half-spin carrier [fcap-0025]
Theorem. Occupation signs split the half-spin carrier [fcap-0025]
Let \(V=W\oplus W'\) be a complex nondegenerate quadratic space of dimension \(2\ell \), with \(\ell \geq 1\). The summands are maximal isotropic and dual under the polar form \(B_Q\). Choose dual bases \(w_i\in W\) and \(w_i'\in W'\) with \(B_Q(w_i,w_j')=\delta _{ij}\). On \(S=\bigwedge W\), write \(u_I\) for the wedge basis vector indexed by \(I\). The even and odd exterior degrees are \(S^+\) and \(S^-\).
The diagonal Clifford bivector of Convention [fcap-000N]
\[\widehat H_i=\beta _Q(w_i,w_i')
=\tfrac 12[\iota _Q(w_i),\iota _Q(w_i')]\]
has factors acting by \(c_i=\varepsilon _{w_i}\) and \(a_i=a_{w_i'}\) in the
notation of Convention [fcap-0027]. Write \(H_i\) for the resulting endomorphism of
\(S\). The relation \(c_i a_i+a_i c_i=1\) gives
\[N_i:=c_i a_i,\qquad
H_i=N_i-\tfrac 12\operatorname {id}_S.\]
Since \(N_i\) projects onto the vectors containing \(i\),
\[H_i u_I=\begin {cases}
\frac 12 u_I,&i\in I,\\
-\frac 12 u_I,&i\notin I.
\end {cases}\]
The simultaneous weight space for each sign pattern is the line
\(\mathbb C u_I\)
TauCeti.spinWeightSpace_spinWeight. The lines
with even \(|I|\) sum to \(S^+\), and those with odd \(|I|\) sum to
\(S^-\). Each half has dimension \(2^{\ell -1}\), while \(S\) has
dimension \(2^\ell \).
For \(\ell =2\), the occupation test gives the complete table \[\begin {array}{c|c|c|c} I&u_I&(H_1,H_2)&\text {summand}\\ \hline \varnothing &1&(-\tfrac 12,-\tfrac 12)&S^+\\ \{1\}&w_1&(\tfrac 12,-\tfrac 12)&S^-\\ \{2\}&w_2&(-\tfrac 12,\tfrac 12)&S^-\\ \{1,2\}&w_1\wedge w_2&(\tfrac 12,\tfrac 12)&S^+ \end {array}\] Every entry is obtained by applying the two rank-one operators of Example [fcap-001P]; the four displayed lines exhaust \(S\) in this case.
Fulton--Harris use \(B_Q=2Q_{\mathrm {FH}}\), so their standard hyperbolic basis becomes polar-dual here after setting \(w_i=e_i\) and \(w_i'=\frac 12e_{\ell +i}\). Their represented operator is then \(L_{e_i}D_{e_i^*}-\frac 12 I=N_i-\frac 12 I\), assigning the same positive sign to an occupied coordinate [fulton2004representation, Proposition 20.15, proof, pp. 305--306]. Thus their occupation signs and even/odd exterior-degree labels agree with the displayed TauCeti axes.
Goodman--Wallach realize the complex spinor carrier as the exterior algebra of the dual isotropic space [goodman2009symmetry, Theorem 6.1.3, proof, pp. 304--305]. Identify their creation space \(W_{\mathrm {GW}}^*\) with \(W\) here, and their annihilation space \(W_{\mathrm {GW}}\) with \(W'\), taking \(w_i=e_{-i}\) and \(w_i'=e_i\).
The reversed order in [goodman2009symmetry, Lemma 6.2.2 and (6.14), p. 313] gives \[\widehat H_i^{\mathrm {Tau}}=\beta _Q(e_{-i},e_i) =-\widehat H_i^{\mathrm {GW}}.\] Accordingly, their occupied eigenvalue \(-\frac 12\) and unoccupied eigenvalue \(+\frac 12\) negate every pair in the table [goodman2009symmetry, Proposition 6.2.3, proof, pp. 314--315]. The exterior vectors and parity labels remain fixed: \(S^+\) means even \(|I|\), and \(S^-\) means odd \(|I|\). This records the occupation operators, weight lines, and parity decomposition, without a root-system, highest-weight, or irreducibility assertion.
Proposition. The simple type-D operators generate the positive nilradical [fcap-002X]AGENTDRAFTED
Proposition. The simple type-D operators generate the positive nilradical [fcap-002X]AGENTDRAFTED
Let \(V=W\oplus W'\) be a complex nondegenerate quadratic space with a chosen split polarization of rank \(\ell \geq 4\). Choose polar-dual bases \(e_i\in W\) and \(e_i'\in W'\) with \(B_Q(e_i,e_j')=\delta _{ij}\), and put \(S=\bigwedge W\). Write \(c_i\) for left creation by \(e_i\), \(a_i\) for contraction by \(e_i'\), \(N_i=c_i a_i\), and \[H_i=N_i-\tfrac 12.\] Thus \(\epsilon _i(H_j)=\delta _{ij}\) fixes the Cartan coordinates, and the occupation signs are those of Theorem [fcap-0025]. We choose \[\Phi ^+=\{\epsilon _i-\epsilon _j,\ \epsilon _i+\epsilon _j:i<j\}\] and the Borel \(\mathfrak b=\mathfrak h\oplus \bigoplus _{\alpha \in \Phi ^+}\mathfrak g_\alpha \). Equivalently, \(\mathfrak b\) stabilizes the flag \(\langle e_1\rangle \subset \langle e_1,e_2\rangle \subset \cdots \subset W\); in the ordered Witt basis \(e_1,\ldots ,e_\ell ,e_\ell ',\ldots ,e_1'\) it is the upper-triangular Borel.
For the simple roots
\(\alpha _i=\epsilon _i-\epsilon _{i+1}\) along the chain and
\(\alpha _\ell =\epsilon _{\ell -1}+\epsilon _\ell \) at the fork, take
\[\begin {aligned}
E_i&=c_i a_{i+1},&F_i&=c_{i+1}a_i
&& (1\leq i<\ell ),\\
E_\ell &=c_{\ell -1}c_\ell ,&
F_\ell &=a_\ell a_{\ell -1}.&&
\end {aligned}\]
The reversed contraction order in \(F_\ell \) fixes the bracket sign. On an
increasing exterior word \(u_I\), a chain operator replaces an occupied
\(i+1\) by an absent \(i\), or performs the reverse replacement, with
coefficient \(1\); otherwise it gives zero. The fork operators create or
remove the final pair, again with coefficient \(1\), when the corresponding
occupancy condition holds. The CAR then gives
\[[E_i,F_i]=h_i,\qquad
h_i=N_i-N_{i+1}\ (i<\ell ),\qquad
h_\ell =N_{\ell -1}+N_\ell -1.\]
Under the bivector map these are the products
\(e_i e_{i+1}'\), \(e_{i+1}e_i'\), \(e_{\ell -1}e_\ell \), and
\(e_\ell 'e_{\ell -1}'\). Distinct orthogonal factors contribute no hidden
scalar term. TauCeti identifies these exact Clifford representatives with
the numbered type-D matrix roots and coroots
TauCeti.SpinPolarizationData.typeDQuadraticEquiv_rootGenerator
TauCeti.SpinPolarizationData.typeDQuadraticEquiv_cartanGenerator.
It remains to pass from the simple roots to the chosen Borel. Put
\[X_{ij}=c_i a_j,\qquad Y_{ij}=c_i c_j\qquad (i<j).\]
Their Cartan weights are \(\epsilon _i-\epsilon _j\) and
\(\epsilon _i+\epsilon _j\). The identities
\[\begin {aligned}
[X_{ij},X_{jk}]&=X_{ik},\\
[X_{i,\ell -1},Y_{\ell -1,\ell }]&=Y_{i,\ell },\\
[X_{j,\ell },Y_{i,\ell }]&=Y_{ij}
\end {aligned}\]
for the indicated distinct ordered indices generate every positive
\(X_{ij}\) and \(Y_{ij}\) from the simple operators. These are all positive
root spaces of \(\mathfrak {so}(V,Q)\), so their span is the full nilradical
\(\mathfrak n^+\). In particular, a vector killed by every \(E_i\) is killed
by \(\mathfrak n^+\): brackets and linear combinations preserve its
annihilator. This final root-space argument supplies the Borel bridge; the
formal file presently proves over \(\mathbb Q\) annihilation by the Lie span
of the simple positive generators, without identifying that span with a
compatible Borel
TauCeti.SpinPolarizationData.typeDSpinSerreRepresentation_positiveSimpleRootLieSpan_le_lieAnnihilator.
Theorem. The two top exterior words are the type-D fork highest vectors [fcap-002Y]AGENTDRAFTED
Theorem. The two top exterior words are the type-D fork highest vectors [fcap-002Y]AGENTDRAFTED
Continue with the Cartan and Borel of Proposition [fcap-002X]. For the increasing exterior basis \(u_I\), set \[\Omega =u_{\{1,\ldots ,\ell \}},\qquad \widehat \Omega =u_{\{1,\ldots ,\ell -1\}}.\] Every positive chain operator kills \(\Omega \) by duplicate creation. It kills \(\widehat \Omega \) either by the same mechanism or, on the final chain edge, because the contracted last coordinate is absent. The positive fork operator kills \(\Omega \) by duplicate creation and \(\widehat \Omega \) because coordinate \(\ell -1\) is already present. The preceding root-space generation therefore makes both vectors highest for \(\mathfrak b\).
Since \(H_i\) has eigenvalue \(+\frac 12\) on an occupied coordinate and \(-\frac 12\) on an unoccupied one, their weights are \[\operatorname {wt}(\Omega ) =\omega _\ell =\tfrac 12(\epsilon _1+\cdots +\epsilon _\ell ),\] \[\operatorname {wt}(\widehat \Omega ) =\omega _{\ell -1} =\tfrac 12(\epsilon _1+\cdots +\epsilon _{\ell -1}-\epsilon _\ell ).\] The first word lies in \(S^+=\bigwedge ^{\mathrm {even}}W\) exactly when \(\ell \) is even, while the second has the opposite parity. Hence, with \(S^\pm \) defined by exterior parity as in Theorem [fcap-0025], \[\begin {array}{c|cc} &S^+&S^-\\ \hline \ell \text { even}&L(\omega _\ell )&L(\omega _{\ell -1})\\ \ell \text { odd}&L(\omega _{\ell -1})&L(\omega _\ell ) \end {array}\] The parity label is therefore not an independent name for the all-plus weight.
For completeness, each displayed module is irreducible for the type-D Lie action. The commuting \(H_i\) have distinct joint eigenvalues on the one-dimensional lines \(\mathbb C u_I\), so polynomial projections in the \(H_i\) extract a nonzero basis word from any nonzero invariant subspace. The chain operators move occupied coordinates, while the fork pair creates or removes two of them. Their occupancy graph connects all subsets of a fixed parity. The invariant subspace consequently contains every basis word of that parity. This proves irreducibility without identifying it with the separate group-level theorem.
The generator calculation is already defined over \(\mathbb Q\). In the
standard model set \(S_{\mathbb Q}=\bigwedge _{\mathbb Q}\mathbb Q^\ell \). The basis
map
\[\begin {aligned}
\mathbb C\otimes _{\mathbb Q}S_{\mathbb Q}
&\longrightarrow \bigwedge _{\mathbb C}\mathbb C^\ell ,\\
z\otimes u_I&\longmapsto z u_I.
\end {aligned}\]
is an equivalence. Every \(E_i\) and \(F_i\) above has matrix entries
\(0,1,-1\); the coroot matrices are integral and the \(H_i\) matrices are
half-integral. Thus these actions, their annihilation identities, and their
weights commute with extension from \(\mathbb Q\) to \(\mathbb C\). A chosen
complex polar-dual basis then transports the standard calculation to
\(W\oplus W'\). TauCeti proves the two simple-generator annihilation
statements and exact fork weights over \(\mathbb Q\)
TauCeti.SpinPolarizationData.typeDSpinRep_serreE_exteriorBasis_univ_eq_zero
TauCeti.SpinPolarizationData.typeDSpinRep_serreE_exteriorBasis_univ_erase_last_eq_zero
TauCeti.SpinPolarizationData.isCartanWeightVector_typeDSpinRep_exteriorBasis_univ
TauCeti.SpinPolarizationData.isCartanWeightVector_typeDSpinRep_exteriorBasis_univ_erase_last.
The displayed scalar-extension and Borel steps explain how this rational
calculation gives the complex highest-weight identities; they do not assert
a packaged Lean base-change theorem.
There are also direct highest-vector counterparts over any
characteristic-zero field. They use a supplied polarization with no residual
line, a basis of \(W\) of rank \(n\geq 4\), and the concrete type-D
Cartan and Borel:
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinLieRep_exteriorBasis_univ
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinLieRep_exteriorBasis_univ_erase_last.
With \(n=\ell \), their zero-based Cartan dual-basis indices \(n-1\) and
\(n-2\) are our \(\omega _\ell \) and \(\omega _{\ell -1}\), respectively.
The restricted declarations also retain the parity assignment in the
table. In even rank, \(\Omega \in S^+\) and
\(\widehat \Omega \in S^-\)
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinPlusLieRep_exteriorBasis_univ_of_even
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinMinusLieRep_exteriorBasis_univ_erase_last_of_even;
in odd rank, \(\Omega \in S^-\) and \(\widehat \Omega \in S^+\)
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinMinusLieRep_exteriorBasis_univ_of_odd
TauCeti.SpinPolarizationData.isHighestWeightVector_typeDSpinPlusLieRep_exteriorBasis_univ_erase_last_of_odd.
These assert highest vectors in the indicated modules; the occupancy
argument above supplies their irreducibility.
[fulton2004representation, Proposition 20.15 and proof, pp. 305--306] independently identify the two irreducible half-spin modules and give the same parity-dependent fork assignment after the polar-dual rescaling already recorded in Theorem [fcap-0025]. Their occupied Cartan sign is positive, as it is here.
[goodman2009symmetry, Proposition 6.2.3, pp. 314--315] independently gives the two irreducible modules and their signed half-sum weights. Its creation space is identified with our \(W\), but its occupied Cartan sign is negative. Under \(H_i^{\mathrm {Tau}}=-H_i^{\mathrm {GW}}\) the weights and positive systems both reverse. The exterior-parity labels remain fixed; the assignment of the two fork highest weights to them must be translated with the Cartan sign and Borel.
Theorem. The top exterior word is the type-B spin highest vector [fcap-002Z]AGENTDRAFTED
Theorem. The top exterior word is the type-B spin highest vector [fcap-002Z]AGENTDRAFTED
Let \(V=W\oplus W'\oplus \mathbb C z\) be a nondegenerate quadratic space of dimension \(2\ell +1\), with \(\ell \geq 1\). Assume \(W,W'\) are complementary polar-dual isotropic spaces, \(z\) is orthogonal to both, and \(Q(z)=1\). Choose bases \(e_i,e_i'\) with \(B_Q(e_i,e_j')=\delta _{ij}\) and the plus odd action on \(S=\bigwedge W\), \[\rho (\iota _Q(z))=\alpha ,\] where \(\alpha \) is exterior parity. This sign is part of the choice: \(Q(z)=1\) alone says only that the line coordinate squares to \(1\). Write \(c_i,a_i,N_i,H_i,\epsilon _i\) as in Theorem [fcap-0025].
Choose the positive roots
\[\Phi ^+=\{\epsilon _i-\epsilon _j,\ \epsilon _i+\epsilon _j:i<j\}
\cup \{\epsilon _i:1\leq i\leq \ell \}.\]
The chain simple roots use \(E_i=c_i a_{i+1}\) and
\(F_i=c_{i+1}a_i\). At the terminal short root
\(\alpha _\ell =\epsilon _\ell \), take
\[E_\ell =c_\ell \alpha ,\qquad
F_\ell =\alpha a_\ell ,\qquad
[E_\ell ,F_\ell ]=2N_\ell -1.\]
The matrix short root has a coefficient \(2\) because
\(B_Q(z,z)=2\); the Clifford bivector is nevertheless exactly
\(e_\ell z\), with no extra factor \(\frac 12\)
TauCeti.SpinPolarizationData.typeBQuadraticEquiv_typeBShortRootGenerator.
On an increasing word, the terminal creation or removal sign cancels the
parity sign, so the short operators insert or remove coordinate \(\ell \)
with coefficient \(1\)
TauCeti.SpinPolarizationData.typeBSpinRep_shortRootGenerator_apply
TauCeti.SpinPolarizationData.typeBSpinRep_shortNegativeRootGenerator_apply.
This convention gives the same flag Borel as in Proposition [fcap-002X]. For \(i<j\), put \(X_{ij}=c_i a_j\), \(Y_{ij}=c_i c_j\), and \(K_i=c_i\alpha \). The chain commutators generate every \(X_{ij}\), while \[[X_{ij},K_j]=K_i,\qquad [K_i,K_j]=-2Y_{ij}.\] Because \(2\) is invertible over \(\mathbb C\), the simple chain operators and \(K_\ell \) generate the root spaces of every positive short and long root. They therefore generate the full positive nilradical.
The top word \[\Omega _B=e_1\wedge \cdots \wedge e_\ell \] is killed by each positive chain root and by \(E_\ell \), since the relevant creation coordinate is already occupied. The chain coroots have eigenvalue \(0\), and the terminal coroot \(2N_\ell -1\) has eigenvalue \(1\). Hence \[\operatorname {wt}(\Omega _B) =\omega _\ell =\tfrac 12(\epsilon _1+\cdots +\epsilon _\ell ).\] The chain moves together with the terminal toggle connect all exterior basis words. As in Theorem [fcap-002Y], the distinct joint \(H_i\)-weights first project any nonzero invariant subspace onto a basis line; the root moves then reach every line. Thus \(S\) is the irreducible type-\(B_\ell \) module \(L(\omega _\ell )\). The short root changes exterior degree, so neither \(S^+\) nor \(S^-\) is a type-B submodule.
[fulton2004representation, Proposition 20.20, p. 307] independently identifies the odd-dimensional spin representation as the irreducible module of highest weight \(\frac 12(\epsilon _1+\cdots +\epsilon _\ell )\). The preceding short-root and nilradical calculations give that conclusion in the fixed FCAP operator convention.
[goodman2009symmetry, Proposition 6.2.4, p. 315]
independently gives the same irreducible type-B module and its half-sign
weights. As in Theorem [fcap-0025], its occupied Cartan sign is opposite ours;
negating its Cartan axes and positive system gives the displayed highest
weight. TauCeti formalizes the short and difference-root actions and the
integral simple-coroot eigenvalues
TauCeti.SpinPolarizationData.typeBSpinRep_differenceRootGenerator_apply
TauCeti.SpinPolarizationData.spinAction_typeBQuadraticEquiv_typeBSimpleCorootGenerator_basis.
The top word's weight and annihilation data are available over any
field with \(2\) invertible, for a supplied polarization, basis of \(W\),
and residual vector \(z\) with \(Q(z)=1\). The Cartan acts on
\(\Omega _B\) through the terminal fundamental weight
TauCeti.SpinPolarizationData.typeBSpinLieRep_apply_cartan_exteriorBasis_univ,
and the Lie subalgebra generated by all positive simple-root generators
annihilates it
TauCeti.SpinPolarizationData.typeBSpinLieRep_lieSpan_range_simpleRootGenerator_le_lieAnnihilator_exteriorBasis_univ.
The declarations index the rank by \(n+1=\ell \); their terminal
\(\operatorname {Fin.last}(n)\) labels our \(\omega _\ell \).
The general highest-vector criterion is available separately:
a nonzero Cartan weight vector is highest exactly when every raising
generator kills it
LieAlgebra.Basis.isHighestWeightVector_iff_forall_e.
It assumes a characteristic-zero field, a finite-dimensional Lie algebra
with nondegenerate Killing form, and a Lie basis. For type B, the Killing
condition follows when every endomorphism in the full standard action is
triangularizable, in particular over \(\mathbb C\)
TauCeti.isKilling_typeB.
Triangularizability of the diagonal Cartan alone is not this hypothesis.
The selected spin-module declarations give the weight and annihilation
data, rather than a separately packaged highest-vector conclusion.
The Borel-generation and irreducibility arguments above complete the
displayed module identification.
Proposition. Exterior weights give the finite spin characters [fcap-0030]AGENTDRAFTED
Proposition. Exterior weights give the finite spin characters [fcap-0030]AGENTDRAFTED
Work over the complex split models and positive systems fixed in the preceding type-B and type-D cards. In type \(B_\ell \) assume \(\ell \geq 1\); in type \(D_\ell \) assume \(\ell \geq 4\). For \(I\subseteq \{1,\ldots ,\ell \}\), put \[\lambda _I=\tfrac 12\left ( \sum _{i\in I}\epsilon _i-\sum _{i\notin I}\epsilon _i\right ).\] By Theorem [fcap-0025], the line \(\mathbb C u_I\) has weight \(\lambda _I\); distinct subsets give distinct weights. Consequently \[\operatorname {ch}S_{B_\ell } =\sum _I e^{\lambda _I} =\prod _{i=1}^{\ell } \left (e^{\epsilon _i/2}+e^{-\epsilon _i/2}\right ),\] and the type-D parity carriers have \[\operatorname {ch}S_D^+ =\sum _{\lvert I\rvert \ {\rm even}}e^{\lambda _I},\qquad \operatorname {ch}S_D^- =\sum _{\lvert I\rvert \ {\rm odd}}e^{\lambda _I}.\] If \(a_i=e^{\epsilon _i/2}\) and \(b_i=e^{-\epsilon _i/2}\), sorting the product by occupied parity gives \[\operatorname {ch}S_D^\pm =\tfrac 12\left [ \prod _i(a_i+b_i)\ \mathbin {\pm }\ \prod _i(b_i-a_i)\right ].\] The order \(b_i-a_i\) makes an occupied coordinate contribute the minus sign. These are finite sums obtained from the exterior basis, without invoking a general character formula.
The complete half-sum weights above become honest characters on the
Spin torus. Put
\(A_i=e_i e_i'\), so its action is \(N_i\). For
\(t\in \mathbb C^\times \), define
\[g_i(t)=tA_i+t^{-1}(1-A_i)
=(t e_i+t^{-1}e_i')(e_i+e_i').\]
Both vector factors have quadratic value \(1\); the pair criterion
therefore puts \(g_i(t)\) in the actual Spin carrier
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
The elements for different coordinates commute, and
\[g_i(t)u_I=
\begin {cases}t\,u_I,&i\in I,\\t^{-1}u_I,&i\notin I.\end {cases}\]
Their vector action scales \(e_i\) by \(t^2\), \(e_i'\) by \(t^{-2}\), and
fixes the other coordinates. Thus
\(g(t_1,\ldots ,t_\ell )=\prod _i g_i(t_i)\) covers the standard orthogonal
torus by coordinatewise squaring.
The kernel of this parameterization is \[\{(t_i):t_i\in \{1,-1\},\ \prod _i t_i=1\}.\] Indeed, equality of its spinor action with the identity forces \(t_i^2=1\) by comparing weights that differ in coordinate \(i\), and the vacuum weight then forces \(\prod _i t_i=1\). Conversely such a tuple gives the actual Clifford scalar \(\prod _i t_i=1\). Thus both implications hold directly for the group parameterization. The image contains the scalar \(-1\); together with the usual \(\{1,-1\}\) kernel of \(\operatorname {Spin}\to SO\) [fulton2004representation, Proposition 20.28, pp. 308--309], this is the full inverse-image torus.
A Laurent monomial on the parameter torus descends through the displayed sign kernel exactly when all its integer exponents have the same parity. Relative to the orthogonal coordinates \(x_i=t_i^2\), the Spin weight lattice is therefore \[P=\mathbb Z^\ell \cup \left (\mathbb Z+\tfrac 12\right )^\ell .\] The complete signed sums \(\lambda _I\) lie in \(P\), while an individual symbol \(e^{\epsilon _i/2}\) need not itself be a character. The orthogonal torus has character lattice \(\mathbb Z^\ell \); every spinor half-sum takes the scalar \(-1\) to \(-1\) and hence does not descend to it. In type D the adjoint torus has the still smaller root lattice.
[goodman2009symmetry, Corollary 6.3.9, p. 322; Sections 7.1 and 7.2.3, pp. 330 and 346] independently identify complex Spin as algebraically simply connected, explain the single-valued square-root torus factors, and identify the torus-character lattice with the weight lattice. Those group results support the character interpretation. The pinned TauCeti results used above are Lie and Clifford statements; no formal integration or differentiation comparison is asserted.
For \(B_2\), the four distinct weights are summarized by \[\operatorname {ch}S_{B_2} =(x^{1/2}+x^{-1/2})(y^{1/2}+y^{-1/2}),\] with highest weight \((\epsilon _1+\epsilon _2)/2=\omega _2\). For \(D_4\), the even- and odd-cardinality sums contain eight weights each: \(\omega _4=(\epsilon _1+\epsilon _2+\epsilon _3+\epsilon _4)/2\) lies in \(S^+\), while \(\omega _3=(\epsilon _1+\epsilon _2+\epsilon _3-\epsilon _4)/2\) lies in \(S^-\). This is a finite character check, not a triality claim.
Proposition. Complex Spin in dimension three is \(SL_2\) on the spin module [fcap-0031]AGENTDRAFTED
Proposition. Complex Spin in dimension three is \(SL_2\) on the spin module [fcap-0031]AGENTDRAFTED
Let \(V\) be a three-dimensional complex quadratic space with a supplied nondegenerate polarization \[V=\mathbb C w\oplus \mathbb C z\oplus \mathbb C w',\qquad B_Q(w,w')=1,\quad Q(z)=1,\] and choose the line coordinate so that \(\rho (z)=\alpha \), exterior parity. On \(S=\bigwedge (\mathbb Cw)\), use the ordered basis \((1,w)\). The even Clifford action then gives a homomorphism \[\operatorname {Spin}(Q)\longrightarrow SL(S)\simeq SL_2(\mathbb C).\] Reversal is matrix adjugation in this basis, so reverse norm one forces determinant one. This is the determinant calculation behind the dimension-three case; the target is the complex group, rather than the compact real unit-quaternion group of Example [fcap-002H].
There is a concrete inverse. For \(c\in \mathbb C\), the two products \[(z+cw)z,\qquad z(z+cw')\] are products of two norm-one vectors and hence are actual Spin elements. Creation, contraction, and parity from Proposition [fcap-002W] give their matrices \[I+cE_{21},\qquad I+cE_{12}\] in the ordered basis \((1,w)\). These elementary transvections generate \(SL_2(\mathbb C)\). Writing a target matrix as a word in them and replacing each factor by its displayed lift gives a preimage; faithfulness of the even Clifford action makes the result independent of the chosen word. Thus restriction and this lift are inverse group maps, and the same basis intertwines the spin action with the standard two-dimensional module.
TauCeti proves this exact group-and-module statement over any field
with \(2\ne 0\), given polarization data and dimension three
TauCeti.exists_spinGroup_mulEquiv_specialLinearGroup_and_spinRep_equiv_stdSLRep_of_finrank_eq_three.
Its chosen finite basis may reindex the two exterior coordinates; the
formulas above use the stated basis \((1,w)\) and the corresponding basis
change. The theorem needs no additional separable-closure hypothesis once
the polarization is supplied.
Fulton--Harris identify \(\operatorname {Spin}_3(\mathbb C)\) with \(SL_2(\mathbb C)\) and distinguish it from the compact real form \(SU(2)\) [fulton2004representation, Section 10.3, pp. 143--144; Exercise 20.39, p. 311]. Goodman--Wallach independently list the same complex exceptional isomorphism [goodman2009symmetry, Section 6.3.3, Exercise 1, p. 322]. Their statements name the target; the two Clifford products above supply the coordinate lifts used here. Meinrenken's \(\operatorname {Spin}(3)=SU(2)\) is instead the compact real comparison [meinrenken2013clifford, Section 3.7.6, p. 83].
Proposition. Complex Spin in dimension four is two copies of \(SL_2\) [fcap-0032]AGENTDRAFTED
Proposition. Complex Spin in dimension four is two copies of \(SL_2\) [fcap-0032]AGENTDRAFTED
Let \(V=W\oplus W'\) be a split nondegenerate complex quadratic
space with \(\dim W=2\), and choose polar-dual bases
\(e_1,e_2\) and \(e'_1,e'_2\). Put
\(S^+=\bigwedge ^{\mathrm {even}}W\) and
\(S^-=\bigwedge ^{\mathrm {odd}}W\), with ordered bases
\((1,e_1\wedge e_2)\) and \((e_1,e_2)\). The paired
half-spin action from Theorem [fcap-002V] gives an algebra equivalence
\[\Phi :\mathcal {C}\kern -2pt\ell (Q)^0\longrightarrow
\operatorname {End}(S^+)\times \operatorname {End}(S^-)
\simeq M_2(\mathbb C)\times M_2(\mathbb C)\]
TauCeti.SpinPolarizationData.evenCliffordEquivProdEnd.
The two factors here are the actions on the fixed exterior-parity
summands, not merely two abstract matrix blocks.
For exterior spinors define \[\langle s,t\rangle = [e_1\wedge e_2]\bigl (\operatorname {rev}_{\wedge }(s)\wedge t\bigr ),\] where the bracket takes the coefficient of \(e_1\wedge e_2\). On each displayed half-spin basis its matrix is \[J=\begin {pmatrix}0&1\\-1&0\end {pmatrix},\] and the two parity summands are orthogonal. Each creation operator and each polar-dual contraction operator is self-adjoint for this pairing, so Clifford reversal becomes the symplectic adjoint on each factor. Consequently, if \(\Phi (x)=(A,D)\), then \[\Phi (\operatorname {rev}(x)) =\bigl (J^{-1}A^{\mathsf T}J,J^{-1}D^{\mathsf T}J\bigr ) =\bigl (\operatorname {adj}(A),\operatorname {adj}(D)\bigr ).\] Therefore \(\operatorname {rev}(x)x=1\) is equivalent to \(\det A=\det D=1\).
We use one carrier-completion observation. In any positive-dimensional
nondegenerate complex quadratic space, suppose an even Clifford unit \(u\)
satisfies \(\operatorname {rev}(u)u=1\) and is already known to normalize
the vector subspace. Its conjugation action is an isometry, so choose a
vector-generated Lipschitz unit with the same orthogonal action
CliffordAlgebra.lipschitzToOrthogonal_surjective.
The quotient of that lift and \(u\) satisfies \(\alpha (z)v=vz\); graded
centrality makes it a nonzero scalar
CliffordAlgebra.exists_eq_algebraMap_of_involute_mul_ι_eq_ι_mul.
Such a scalar unit is Lipschitz
CliffordAlgebra.unitsMap_algebraMap_mem_lipschitzGroup.
Hence \(u\) is Lipschitz, even, and reverse-norm one, and the exact carrier
criterion of Remark [fcap-0028] puts it in Spin.
The forward restriction is thus a group homomorphism \[\operatorname {Spin}(Q)\longrightarrow SL(S^+)\times SL(S^-).\] Conversely, take \((A,D)\in SL_2(\mathbb C)\times SL_2(\mathbb C)\) and let \(x=\Phi ^{-1}(A,D)\). The adjugate calculation makes \(x\) an even Clifford unit with \(\operatorname {rev}(x)x=1\). It remains to prove that this algebraic preimage lies in the actual vector-generated Spin group.
For \(v\in V\), set \(y=xvx^{-1}\). It is odd and reversal-fixed: \[\operatorname {rev}(y) =\operatorname {rev}(x^{-1})v\operatorname {rev}(x)=y.\] In an orthogonal-basis Clifford expansion in dimension four, the odd part has only grades one and three. Reversal has signs \(+1\) and \(-1\) on those grades, so \(y\in V\). Moreover \(y^2=Q(v)1\); conjugation hence induces an isometry of \((V,Q)\). The carrier-completion observation now places \(x\) in the actual Spin group.
The restriction and \((A,D)\mapsto \Phi ^{-1}(A,D)\) are now inverse group maps. Hence \[\operatorname {Spin}_4(\mathbb C)\simeq SL_2(\mathbb C)\times SL_2(\mathbb C),\] and the two half-spin representations are the two standard two-dimensional modules. [fulton2004representation, Exercise 20.39, p. 311] state this group-and-module identification. [goodman2009symmetry, Section 6.3.3, Exercise 1, p. 322] independently give the same complex group. The displayed pairing, adjugate calculation, and carrier argument provide the inverse.
[meinrenken2013clifford, Section 3.7.6, p. 83]
identifies the compact real form as \(\operatorname {Spin}(4)=SU(2)\times SU(2)\). Its
quaternion-pair model is Example [fcap-002K], while the Lorentzian real form
\(SL_2(\mathbb C)\) is Example [fcap-002L]; neither replaces the split complex
proof above. TauCeti formalizes the paired half-spin algebra and matrix maps
TauCeti.SpinPolarizationData.evenCliffordEquivProdMatrix.
The actual group and both modules also have a direct formal counterpart
TauCeti.exists_spinGroup_mulEquiv_specialLinearGroup_prod_and_halfSpin_equiv_stdSLRep_of_finrank_eq_four.
For a supplied polarization over a field of characteristic different from
two and ambient dimension four, it constructs a group equivalence
\(\operatorname {Spin}(Q)\simeq SL_2(K)\times SL_2(K)\) together with equivalences from
the existing plus and minus half-spin subrepresentations to the standard
representations pulled back from the first and second factors.
The dimension hypothesis forces the residual line to vanish. The theorem
chooses bases of both half-spin spaces, so its matrix coordinates agree
with the ordered bases used here after basis transport. The displayed
pairing and carrier proof give the comparison in our explicit coordinates.
Proposition. Complex Spin in dimension five is the symplectic group on spinors [fcap-0033]AGENTDRAFTED
Proposition. Complex Spin in dimension five is the symplectic group on spinors [fcap-0033]AGENTDRAFTED
Let \(V=W\oplus \mathbb Cz\oplus W'\) be a five-dimensional complex
quadratic space with a supplied nondegenerate polarization, where
\(\dim W=2\), \(Q(z)=1\), and \(\rho (z)=\alpha \). On
\(S=\bigwedge W\), use the ordered basis
\[(1,e_1\wedge e_2,e_1,e_2).\]
Define
\[\langle s,t\rangle =
[e_1\wedge e_2]\bigl (\operatorname {rev}_{\wedge }(s)\wedge t\bigr ).\]
Its matrix is \(\Omega =\operatorname {diag}(J,J)\), where
\(J=\left (\begin {smallmatrix}0&1\\-1&0\end {smallmatrix}\right )\).
The pairing preserves exterior parity, so parity itself is self-adjoint.
Each creation operator and each polar-dual contraction operator is
self-adjoint as well. Consequently the faithful
even Clifford equivalence from Proposition [fcap-002W] takes reversal to
\[A\longmapsto A^{\dagger }
=\Omega ^{-1}A^{\mathsf T}\Omega \]
TauCeti.SpinPolarizationData.evenCliffordEquivEnd.
Reverse norm one is therefore exactly the symplectic equation
\(A^{\mathsf T}\Omega A=\Omega \).
This norm calculation alone does not yet prove membership in the vector-generated Spin group. The five vector operators \[c_1,\ c_2,\ a_1,\ a_2,\ \alpha \] are linearly independent, traceless, and \(\Omega \)-self-adjoint. The self-adjoint subspace of \(M_4(\mathbb C)\) has dimension six, and its trace-zero part has dimension five because \(\operatorname {tr}(I)=4\). Hence the Clifford image of the vector space is exactly \[\rho (V)= \{T:T^{\dagger }=T,\ \operatorname {tr}(T)=0\}.\] Conjugation by every \(A\in Sp_{\Omega }(4,\mathbb C)\) preserves this subspace: symplectic conjugation preserves the adjoint condition, and trace is conjugation-invariant.
The odd Clifford action is injective on the vector subspace. More generally, if an odd Clifford value \(y\) acts by zero, then \(zy\) is even and acts by zero. Faithfulness of the even action and invertibility of \(z\) give \(y=0\). Thus preservation of the displayed matrix subspace lifts to preservation of \(V\) inside the Clifford algebra.
For \(A\in Sp_{\Omega }(4,\mathbb C)\), let \(x\) be its unique preimage under the even Clifford equivalence. The adjoint equation gives \(\operatorname {rev}(x)x=1\), while the preceding calculation proves \(xVx^{-1}=V\). The carrier-completion argument of Proposition [fcap-0032] now places \(x\) in actual Spin. Conversely, every Spin element has symplectic matrix because its reverse norm is one. These assignments are inverse group maps, and the chosen exterior basis is the module intertwiner: \[\operatorname {Spin}_5(\mathbb C)\simeq Sp_{\Omega }(4,\mathbb C), \qquad S\simeq \mathbb C^4.\]
Fulton--Harris state the same group and standard spin-module identification [fulton2004representation, Exercise 20.39, p. 311]. Goodman--Wallach independently write the target as \(Sp(2,\mathbb C)\), the rank-two symplectic group on a four-dimensional complex space [goodman2009symmetry, Section 6.3.3, Exercise 1, p. 322]. The trace-zero normalization calculation supplies the actual group inverse rather than inferring the image from a dimension count. By contrast, Meinrenken's \(\operatorname {Spin}(5)=Sp(2)\) is the compact quaternionic real form [meinrenken2013clifford, Section 3.7.6, pp. 83--84].
TauCeti proves that in odd dimension the even Clifford action is an
equivalence onto the full endomorphism algebra and is faithful
TauCeti.SpinPolarizationData.evenCliffordEquivEnd
TauCeti.evenSpinAction_injective.
It does not package the invariant alternating form or the group image as
\(Sp_4\); those calculations are the explicit argument above.
Proposition. Complex Spin in dimension six is \(SL_4\) on a half-spin module [fcap-0034]AGENTDRAFTED
Proposition. Complex Spin in dimension six is \(SL_4\) on a half-spin module [fcap-0034]AGENTDRAFTED
Let \(V=W\oplus W'\) be a split nondegenerate complex quadratic space with \(\dim W=3\). For polar-dual bases \(e_i,e'_i\), use \[S^+:(1,e_{12},e_{13},e_{23}),\qquad S^-:(e_{123},-e_3,e_2,-e_1).\] For \(\langle s,t\rangle =[e_{123}]\bigl ( \operatorname {rev}_{\wedge }(s)\wedge t\bigr )\), the second displayed basis is dual to the first, and the full pairing matrix on \(S^+\oplus S^-\) is \[\Omega =\begin {pmatrix}0&I_4\\-I_4&0\end {pmatrix}.\] Clifford generators are self-adjoint for this pairing. Under the paired even-algebra equivalence \(\Phi \) of Theorem [fcap-002V], reversal therefore sends \[(A,D)\longmapsto (D^{\mathsf T},A^{\mathsf T}).\] Thus the even reverse-norm-one group is \[\{(A,A^{-\mathsf T}):A\in GL_4(\mathbb C)\}.\] At this stage it is \(GL_4\), not yet the actual Spin group.
The vector-normalization condition cuts out the determinant-one subgroup. If \(v=\sum _i x_i e_i+y_i e'_i\), its odd Clifford action has block form \[\rho (v)=\begin {pmatrix}0&B_v\\B_v^\sharp &0\end {pmatrix},\] where \[B_v=\begin {pmatrix} 0&-y_3&y_2&-y_1\\ y_3&0&x_1&x_2\\ -y_2&-x_1&0&x_3\\ y_1&-x_2&-x_3&0 \end {pmatrix}.\] These matrices run through all skew \(4\times 4\) matrices. For a skew matrix \(B\), define \(B^\sharp \) by \[\begin {aligned} (B^\sharp )_{01}&=B_{23},& (B^\sharp )_{02}&=-B_{13},& (B^\sharp )_{03}&=B_{12},\\ (B^\sharp )_{12}&=B_{03},& (B^\sharp )_{13}&=-B_{02},& (B^\sharp )_{23}&=B_{01}, \end {aligned}\] with skew extension. Then \((B^\sharp )^\sharp =B\), \(BB^\sharp =-\operatorname {Pf}(B)I\), and \(\operatorname {Pf}(B_v)=-\sum _i x_i y_i\). The last two identities give \(\rho (v)^2=Q(v)I\), matching the Clifford convention.
The complementary-minor identity is \[(ABA^{\mathsf T})^\sharp =\det (A)A^{-\mathsf T}B^\sharp A^{-1}.\] One derivation identifies a skew matrix with an alternating two-form: the operation \(B\mapsto B^\sharp \) is the complementary two-form determined by the ordered volume basis, while \(\bigwedge ^4 A\) multiplies that volume by \(\det A\). Evaluating on basis pairs gives the six coordinate rules above and the displayed identity.
Conjugation by \(\operatorname {diag}(A,A^{-\mathsf T})\) sends the two off-diagonal blocks to \[ABA^{\mathsf T},\qquad A^{-\mathsf T}B^\sharp A^{-1}.\] By the complementary-minor identity, it preserves the vector graph \(\{(B,B^\sharp ):B^{\mathsf T}=-B\}\) exactly when \(\det A=1\). Sufficiency is immediate. For necessity, choose any nonzero \(B^\sharp \); equality of the two lower blocks forces \(\det A=1\). Faithfulness of the full Clifford action in this even dimension lifts this matrix statement to normalization of the actual vector subspace.
Every Spin element therefore acts on \(S^+\) through \(SL_4(\mathbb C)\). Conversely, for \(A\in SL_4(\mathbb C)\), let \(x\) be the unique even Clifford preimage of \((A,A^{-\mathsf T})\). It has reverse norm one and, by the graph calculation, normalizes \(V\). The carrier-completion argument of Proposition [fcap-0032] places \(x\) in actual Spin. The mutually inverse maps are \[g\longmapsto \rho _+(g),\qquad A\longmapsto \Phi ^{-1}(A,A^{-\mathsf T}).\] Hence \[\operatorname {Spin}_6(\mathbb C)\simeq SL_4(\mathbb C).\] In the displayed bases \(S^+\) is the standard four-dimensional module and \(S^-\) is its dual.
[fulton2004representation, Exercise 20.39, p. 311] give the group and standard \(S^+\) module. [goodman2009symmetry, Section 6.3.3, Exercise 1, p. 322] independently give the same complex group. Here the cross-pairing proves \(S^-\) is dual, and the vector-graph calculation proves the actual image.
[meinrenken2013clifford, Section 3.7.6, p. 84] gives the compact real form \(\operatorname {Spin}(6)=SU(4)\).
TauCeti formalizes the paired half-spin algebra and matrix equivalences
TauCeti.SpinPolarizationData.evenCliffordEquivProdEnd
TauCeti.SpinPolarizationData.evenCliffordEquivProdMatrix.
The vector graph, determinant-one group image and inverse are proved above,
not by these declarations.
Proposition. The outer nodes of \(D_4\) permute the three eight-dimensional classes [fcap-003B]AGENTDRAFTED
Proposition. The outer nodes of \(D_4\) permute the three eight-dimensional classes [fcap-003B]AGENTDRAFTED
Work over \(\mathbb C\) with the type-\(D_4\) Cartan and Borel of Proposition [fcap-002X]. In its orthonormal coordinates put \[\begin {aligned} \alpha _1&=\epsilon _1-\epsilon _2,& \alpha _2&=\epsilon _2-\epsilon _3,\\ \alpha _3&=\epsilon _3-\epsilon _4,& \alpha _4&=\epsilon _3+\epsilon _4. \end {aligned}\] The central node is \(2\); the outer nodes are \(1,3,4\). Their fundamental weights are \[\omega _1=\epsilon _1,\qquad \omega _3=\tfrac 12(\epsilon _1+\epsilon _2+\epsilon _3-\epsilon _4),\qquad \omega _4=\tfrac 12(\epsilon _1+\epsilon _2+\epsilon _3+\epsilon _4).\] The established exterior convention identifies the vector class with \(L(\omega _1)\), the all-plus half-spin class with \(S^+=L(\omega _4)\), and the other half-spin class with \(S^-=L(\omega _3)\); see Theorem [fcap-002Y] and Proposition [fcap-0030]. Each has dimension eight.
Let \(\sigma \) be any permutation of \(\{1,3,4\}\). The linear map specified on the simple-root basis by \[T_\sigma (\alpha _i)=\alpha _{\sigma (i)}\quad (i=1,3,4),\qquad T_\sigma (\alpha _2)=\alpha _2\] preserves the \(D_4\) Cartan matrix. Hence it is orthogonal, preserves the root and coroot systems, and preserves the weight and coweight lattices. It is therefore an automorphism of the simply connected based root datum. Duality with the simple coroots gives \[T_\sigma (\omega _i)=\omega _{\sigma (i)}\qquad (i=1,3,4).\] In particular an outer three-cycle has cube one and nontrivially cycles the three labeled highest-weight classes \[L(\omega _1),\qquad S^-=L(\omega _3),\qquad S^+=L(\omega _4).\] This is a permutation of based root data and of irreducible highest-weight labels. A literal pullback of concrete group modules would additionally require an actual group automorphism and a fixed direction; that stronger statement is not inferred from this diagram calculation.
[fulton2004representation, Section 20.3, pp. 312--314] give the same \(D_4\) diagram and identify the vector and two half-spin highest weights. [adams1996exceptional, Chapter 5, Theorem 5.6, pp. 33--35] independently identifies these as the three basic eight-dimensional classes permuted by outer automorphisms. The first source is the complex highest-weight comparison used here; Adams' theorem concerns the compact actual group and is not being claimed as proved by the root-datum calculation alone.
The pinned declaration
TauCeti.D4Tripled.trialityAutomorphism
has cube one on a tripled type-\(D_4\) toral-closure carrier and permutes
its numbered root and represented-torus coordinates. The inspected file
does not identify that carrier with standard \(\operatorname {Spin}_8\), prove its torus
maximal, or identify its three factors with the vector and half-spin
modules. It is precise formal context for the diagram symmetry, not a
whole-card formalization of the proposition above.
Theorem. The actual compact \(\operatorname {Spin}(8)\) has outer Lie-automorphism group \(S_3\) [fcap-003C]AGENTDRAFTED
Theorem. The actual compact \(\operatorname {Spin}(8)\) has outer Lie-automorphism group \(S_3\) [fcap-003C]AGENTDRAFTED
Let \(Q_8^+\) be the positive quadratic form on \(\mathbb R^8\), and let \[G=\operatorname {Spin}(Q_8^+)\longrightarrow SO(8)\] be the actual vector-generated, reverse-norm-one carrier and its vector action \(\pi \). The concrete Lie-group and covering results of Proposition [fcap-0037] and Proposition [fcap-003A] make \(G\) compact, connected, and simply connected, with \(\pi \) its two-sheeted universal cover. The even-word sign-change map of Proposition [fcap-0039] identifies this positive-square carrier with the compact negative-square convention used in the classical source, compatibly with the vector action.
Let \(\nu _+\) and \(\nu _-\) be the two real eight-dimensional half-spin representations. Their complexifications have highest weights \(\omega _4\) and \(\omega _3\), so the comparison of Proposition [fcap-003B] and the exterior construction of Theorem [fcap-002Y] identify them, up to chosen intertwiners, with the two concrete complex half-spin modules. Average a positive definite inner product over compact \(G\). In an orthonormal basis either representation gives \[\nu :G\longrightarrow O(8).\] Connectedness puts its image in \(SO(8)\). Since \(G\) is simply connected, the universal cover \(\pi \) has a unique based lift \[\Theta :G\longrightarrow G,\qquad \pi \circ \Theta =\nu .\] The two maps \(\Theta (xy)\) and \(\Theta (x)\Theta (y)\) are based lifts on the connected space \(G\times G\), so uniqueness makes \(\Theta \) a group homomorphism.
Its derivative is nonzero because the half-spin representation has nonzero weights. The kernel of the derivative is an ideal of the simple Lie algebra \(\mathfrak {so}_8\), hence it is zero. Equal dimensions make \(\Theta \) a local Lie-group isomorphism. Its image is open, and compactness makes it closed; connectedness of \(G\) makes the image all of \(G\). Thus \(\Theta \) is a covering of a simply connected target by a connected source and is a Lie-group automorphism. Let Lie-group automorphisms act on representation classes by inverse pullback, \[\varphi \mathbin {\cdot }[M]=[M\circ \varphi ^{-1}].\] With this left-action convention, \(\Theta ^{-1}\) sends the vector class to the chosen half-spin class because \(\pi \circ \Theta =\nu \).
Every Lie-group automorphism permutes the three classes. After inner conjugation it preserves a chosen maximal torus and positive Weyl chamber; its differential therefore induces a based \(D_4\) root-datum automorphism. The diagram calculation of Proposition [fcap-003B] shows that it permutes precisely the outer-node weights \(\omega _1,\omega _3,\omega _4\). Inner automorphisms act trivially on isomorphism classes, so inverse pullback defines a homomorphism \[\operatorname {Out}_{\mathrm {Lie}}(G)\longrightarrow S_3.\] There is a second kind of actual Lie-group automorphism. Conjugation by any unit vector in the Clifford algebra preserves even vector products and reverse norm and has conjugation by its inverse as inverse. On the vector module it gives orthogonal conjugation of \(\pi \); on the odd Clifford action it interchanges \(S^+\) and \(S^-\). Its permutation fixes the vector class and swaps the two half-spin classes. Together with the lifted half-spin automorphism, these permutations generate \(S_3\).
This permutation action has inner kernel. Suppose an automorphism \(\varphi \) fixes all three representation classes. Equivalence of \(\pi \circ \varphi \) with \(\pi \) gives an intertwiner; after polar normalization it is a matrix \(A\in O(8)\). If \(\det A=1\), lift \(A\) to \(g\in G\). After composing \(\varphi \) with the inverse inner automorphism \(\operatorname {Int}(g)\), its projection agrees with \(\pi \). The pointwise discrepancy from the identity lies continuously in \(\ker \pi =\{1,-1\}\), hence is identically \(1\) on connected \(G\). The remaining automorphism is the identity. If \(\det A=-1\), first compose with unit-vector conjugation. The result is inner by the preceding case, but unit-vector conjugation swaps the two half-spin classes, contradicting the hypothesis. Therefore \[\operatorname {Out}_{\mathrm {Lie}}(G)\simeq S_3.\] A suitable composition of the two constructed outer classes maps to a three-cycle and therefore has order three in the outer group. This does not show that the chosen half-spin lift \(\Theta \) has order three, and no representative has been normalized here to cube to the identity. No splitting \(S_3\to \operatorname {Aut}_{\mathrm {Lie}}(G)\) is asserted.
[adams1996exceptional, Chapter 5, Theorem 5.6, pp. 34--35] proves the compact group theorem and the permutation of its three eight-dimensional representations. [fulton2004representation, Section 20.3, pp. 312--314] independently describe the corresponding complex vector/half-spin triality and root diagram. The carrier translation, universal-cover lift, surjectivity, and kernel argument above place that comparison on the actual FCAP Spin group.
The pinned declaration
TauCeti.D4Tripled.trialityAutomorphism
has literal cube one on a tripled toral-closure carrier. Its source file
does not identify that carrier with the actual group \(G\). Accordingly it
is not used to claim cube one for \(\Theta \) or as a formal badge for this
theorem.
Proposition. Clifford multiplication gives the triality trilinear [fcap-003D]AGENTDRAFTED
Proposition. Clifford multiplication gives the triality trilinear [fcap-003D]AGENTDRAFTED
Complexify the compact model and use the split rank-four exterior carrier \(S=\bigwedge W\) with a chosen top form \(\operatorname {vol}=e_1\wedge e_2\wedge e_3\wedge e_4\). Define \[B(s,t)=[\operatorname {rev}_{\wedge }(s)\wedge t]_{\operatorname {vol}}.\] In degree four this form is symmetric; its restrictions \(B_+\) and \(B_-\) to \(S^+\) and \(S^-\) are nondegenerate. Each creation operator and each polar-dual contraction operator is individually self-adjoint for \(B\). Thus the adjoint of Clifford multiplication by \(x\) is multiplication by \(\operatorname {rev}(x)\), and actual Spin elements preserve \(B\).
For \(v\in V\), \(s_+\in S^+\), and \(s_-\in S^-\), put \[F(v,s_+,s_-)=B_-(\rho (v)s_+,s_-).\] Clifford covariance of \(\rho (v)\) and invariance of \(B\) give \[F(\pi (g)v,\rho _+(g)s_+,\rho _-(g)s_-)=F(v,s_+,s_-) \qquad (g\in \operatorname {Spin}_8).\] The form is nonzero: with the displayed orientation, \[F(e_1,1,e_2\wedge e_3\wedge e_4)=1.\] This is an explicit invariant tensor \(V\otimes S^+\otimes S^-\to \mathbb C\); changing the chosen top form rescales it.
It is unique up to scalar. The full odd Clifford range is \[\operatorname {Hom}(S^+,S^-)\oplus \operatorname {Hom}(S^-,S^+).\] Under equivariant antisymmetrization its degrees are \(1,3,5,7\). Multiplication by the normalized Clifford volume element of the eight-dimensional space \(V\) exchanges degrees \(k\) and \(8-k\); projecting to either chirality block therefore gives \[\operatorname {Hom}(S^+,S^-)\simeq V\oplus \bigwedge ^3V.\] The two summands are nonisomorphic irreducible \(\operatorname {Spin}_8\)-modules, so \(V\) occurs exactly once. The nondegenerate forms identify invariant trilinears with \(\operatorname {Hom}_{\operatorname {Spin}_8}(V,S^+\otimes S^-)\), which is therefore one-dimensional.
[adams1996exceptional, Chapter 5, Proposition 5.7, pp. 35--36] states the invariant trilinear and proves the required multiplicity-one decomposition.
[fulton2004representation, Section 20.3, pp. 313--314] independently construct the Clifford-multiplication trilinear in the complex modules. The displayed top-form formula fixes its normalization in the FCAP creation--contraction convention. It does not assert a normed composition algebra or an order-three isometry of the tensor.
Theorem. A pinned three-cycle integrates to compact triality [fcap-003T]AGENTDRAFTED
Theorem. A pinned three-cycle integrates to compact triality [fcap-003T]AGENTDRAFTED
Let \(G=\operatorname {Spin}(Q_8^+)\) be the compact positive-square Clifford group, and let \(V\) denote its complexified vector representation. There is a smooth outer automorphism \(\tau :G\to G\) of exact order three for which \[V\circ \tau \simeq S^+,\qquad V\circ \tau ^2\simeq S^-.\] Here \(S^+=L(\omega _4)\) and \(S^-=L(\omega _3)\) use the exterior convention of Proposition [fcap-003B]. These are literal pullbacks of representations of the compact real group.
Proof.
Proof.
Choose a real orthonormal basis \(a_i,b_i\), \(1\leq i\leq 4\), and set \(u_i=(a_i+\mathrm i b_i)/2\), \(u_i'=\overline {u_i}\). Since \(B_Q=2\langle \ ,\ \rangle \), these are polar-dual isotropic bases. In the complexified Clifford algebra, \[u_i u_j'+u_j'u_i=\delta _{ij},\qquad u_i u_j+u_j u_i=u_i'u_j'+u_j'u_i'=0.\] Use precisely the quadratic generators of Proposition [fcap-002X]: \[\begin {aligned} H_i&=u_i u_i'-\tfrac 12,\\ E_i&=u_i u_{i+1}',&F_i&=u_{i+1}u_i',&h_i&=H_i-H_{i+1} && (i<4),\\ E_4&=u_3u_4,&F_4&=u_4'u_3',&h_4&=H_3+H_4. \end {aligned}\] They belong to the complexified quadratic Lie algebra \(\mathfrak g_{\mathbb C}\) of Proposition [fcap-0037]. The simple roots are \(\epsilon _i-\epsilon _{i+1}\) for \(i<4\) and \(\epsilon _3+\epsilon _4\) for node \(4\); node \(2\) is central.
Let \(A\) be the corresponding \(D_4\) Cartan matrix: its diagonal entries are \(2\), adjacent-node entries \(-1\), and all others \(0\). The displayed Clifford relations give \[\begin {aligned} [h_i,h_j]&=0,&[E_i,F_j]&=\delta _{ij}h_i,\\ [h_i,E_j]&=A_{ij}E_j,&[h_i,F_j]&=-A_{ij}F_j, \end {aligned}\] \[\begin {aligned} (\operatorname {ad}E_i)^{1-A_{ij}}E_j&=0,\\ (\operatorname {ad}F_i)^{1-A_{ij}}F_j&=0\qquad (i\ne j). \end {aligned}\] The positive-root generation in Proposition [fcap-002X], its lowering counterpart and the brackets \([E_i,F_i]\) generate all of \(\mathfrak g_{\mathbb C}\). The Serre presentation and pinned extension theorem in [fulton2004representation, Section 21.3, pp. 337--338] therefore apply to this Lie algebra.
The permutation \(\sigma =(1\ 3\ 4)\), fixing \(2\), preserves \(A\). Reindexing each generator family preserves the presentation, so it defines a unique complex Lie automorphism \(\theta \) with \[\theta (E_i)=E_{\sigma (i)},\qquad \theta (F_i)=F_{\sigma (i)},\qquad \theta (h_i)=h_{\sigma (i)}.\] Inverse reindexing supplies its inverse. Its cube fixes all generators, hence \(\theta ^3=1\).
The compact real form must also be preserved. Let \(\kappa \) be conjugation of the complexified real Clifford algebra. The same Clifford relations, with the reversed factor order in \(F_4\), give \[\begin {aligned} \kappa (H_i)&=u_i'u_i-\tfrac 12=-H_i,\\ \kappa (E_i)&=u_i'u_{i+1}=-F_i&& (i<4),\\ \kappa (E_4)&=u_3'u_4'=-F_4. \end {aligned}\] Also \(\kappa (F_i)=-E_i\) and \(\kappa (h_i)=-h_i\). Thus the antilinear maps \(\kappa \theta \) and \(\theta \kappa \) agree on the generators and everywhere. By Proposition [fcap-0037], the \(\kappa \)-fixed quadratic Lie algebra is exactly \(T_1G\). Consequently \(\theta \) restricts to a real Lie automorphism of the actual compact group's tangent algebra.
The group \(G\) is connected and simply connected by Proposition [fcap-003A]. The general group-to-group integration theorem, the Second Principle in [fulton2004representation, pp. 118--119], therefore integrates this restriction to a smooth homomorphism \(\tau :G\to G\). Its graph-subgroup proof is the construction in Theorem [fcap-003L] with target \(G\): first projection is a surjective covering and hence an isomorphism. Integrating \(\theta ^{-1}\) too gives the inverse of \(\tau \), because a homomorphism from connected \(G\) is determined by its differential. Indeed, equal differentials give equality on an exponential neighborhood, which generates \(G\). The same uniqueness proves \(\tau ^3=1\).
For a highest weight \(\omega _j\), literal pullback along \(\theta \) gives \[(\omega _j\circ \theta )(h_i)=\delta _{j,\sigma (i)} =\omega _{\sigma ^{-1}(j)}(h_i).\] Since \(\theta \) also permutes the positive generators, the new highest weight is \(\omega _{\sigma ^{-1}(j)}\). Starting with \(V=L(\omega _1)\), the pullbacks therefore have labels \(\omega _1,\omega _4,\omega _3\): they are \(V,S^+,S^-\) in that order. These are distinct irreducible classes. Inner automorphisms preserve each representation class, so \(\tau \) is outer and nontrivial; together with \(\tau ^3=1\), this proves exact order three.
The outer-class calculation in Theorem [fcap-003C] is thereby realized by a chosen cube-one automorphism. TauCeti's Serre diagram automorphism formalizes generator reindexing and its order relation on the presented Lie algebra. Its compact real-form identification and integration to this Clifford group are additional steps proved above. The tripled-carrier automorphism discussed in Proposition [fcap-003B] remains a different construction.
Theorem. Triality cycles three real modules and preserves the trilinear [fcap-003U]AGENTDRAFTED
Theorem. Triality cycles three real modules and preserves the trilinear [fcap-003U]AGENTDRAFTED
For the automorphism \(\tau \) of Theorem [fcap-003T], one can choose real forms of \(S^+,S^-\), invariant positive inner products on them, and real isometries \[J_0:V_{\mathbb R}\longrightarrow S^+_{\mathbb R},\qquad J_1:S^+_{\mathbb R}\longrightarrow S^-_{\mathbb R},\qquad J_2:S^-_{\mathbb R}\longrightarrow V_{\mathbb R}\] whose cyclic direct-sum map \(J\) has \(J^3=1\). Their complex-linear extensions preserve exactly the trilinear \(F\) of Proposition [fcap-003D]: \[F(J_2s_-,J_0v,J_1s_+)=F(v,s_+,s_-).\] The chosen forward cycle intertwines the diagonal group action with \(\tau ^{-1}\). The real forms and inner products are specified in the construction below.
Proof.
Proof.
Let \(E=\mathbb R^8\) with its Euclidean inner product, and let \(\pi :G\to SO(E)\) be the vector action. On three copies of this same real space define the twisted modules \[V_i=(E,\pi \circ \tau ^i),\qquad i\in \mathbb Z/3\mathbb Z.\] Their complexifications have classes \(V,S^+,S^-\), respectively, by Theorem [fcap-003T]. Thus Proposition [fcap-003D] gives a one-dimensional complex space of invariant trilinears on their complexifications.
The invariance equations on \(E^{\otimes 3}\) have real coefficients. The real and imaginary parts of every invariant complex trilinear are therefore invariant real trilinears. It follows that \[L=(V_0^*\otimes _{\mathbb R}V_1^*\otimes _{\mathbb R}V_2^*)^G, \qquad \dim _{\mathbb R}L=1,\] because complexification identifies \(L\otimes _{\mathbb R}\mathbb C\) with the invariant complex space. Choose \(0\ne t\in L\).
Write \[D(g)=\operatorname {diag}\bigl (\pi (g),\pi (\tau g), \pi (\tau ^2g)\bigr ).\] Define \(Ct(x_0,x_1,x_2)=t(x_1,x_2,x_0)\) using the common underlying space \(E\). Permuting \(D(g)(x_0,x_1,x_2)\) this way gives \(D(\tau g)(x_1,x_2,x_0)\), so \(C\) preserves \(L\). Moreover \(C^3=1\). On a real one-dimensional space this means \(C=c\) for a real scalar with \(c^3=1\); hence \(c=1\). In particular, \[t(x_0,x_1,x_2)=t(x_1,x_2,x_0)=t(x_2,x_0,x_1).\] The real field is essential here: over \(\mathbb C\), a cube-one scalar need not be one.
Choose complex \(G\)-module isomorphisms \[\phi _0=1:V_{0,\mathbb C}\to V,\qquad \phi _1:V_{1,\mathbb C}\to S^+,\qquad \phi _2:V_{2,\mathbb C}\to S^-.\] They exist by the proved representation comparisons. The pullback of \(F\) along these maps is \(\lambda t_{\mathbb C}\) for some \(\lambda \ne 0\). Multiplying \(\phi _1\) by a unit complex scalar makes \(\lambda \) real. Now define \(S^+_{\mathbb R}=\phi _1(E)\) and \(S^-_{\mathbb R}=\phi _2(E)\), with inner products transported from \(E\). They are \(G\)-invariant real forms with positive inner products, and the restriction of \(F\) to these three real forms is real-valued.
Set \[J_0=\phi _1\phi _0^{-1},\qquad J_1=\phi _2\phi _1^{-1},\qquad J_2=\phi _0\phi _2^{-1}.\] In these formulas the underlying copies of \(E\) are identified; the maps relate differently twisted actions. Each is a real isometry for the stated metrics, and each cyclic composite of all three is the identity. With \(\Phi =\phi _0\oplus \phi _1\oplus \phi _2\), let \(J=\Phi J_E\Phi ^{-1}\), where \(J_E(x_0,x_1,x_2)=(x_2,x_0,x_1)\). Thus \(J^3=1\).
The diagonal action on \(V\oplus S^+\oplus S^-\) is \(\mathcal D(g)=\Phi D(g)\Phi ^{-1}\). In the common coordinates, \[J_E D(g)=D(\tau ^{-1}g)J_E,\] so \(J\mathcal D(g)=\mathcal D(\tau ^{-1}g)J\). Finally the cyclic identity for \(t\) gives \[\begin {aligned} F(J_2s_-,J_0v,J_1s_+) &=\lambda t_{\mathbb C}(x_2,x_0,x_1)\\ &=\lambda t_{\mathbb C}(x_0,x_1,x_2) =F(v,s_+,s_-), \end {aligned}\] where \(v=\phi _0x_0\), \(s_+=\phi _1x_1\), and \(s_-=\phi _2x_2\). No rescaling of \(F\) was made, so its top-form normalization in Proposition [fcap-003D] is retained.
Proposition 5.7 in [adams1996exceptional, pp. 35--36] supplies the invariant-line and real-valued trilinear statements.
Exercises 20.50--20.51 in [fulton2004representation, pp. 314--315] describe the related cyclic tensor symmetry. The construction above obtains that symmetry from the chosen compact automorphism and the real invariant line. Its isometry claim uses the transported inner products just defined; it does not identify them with preselected exterior bilinear forms or assert a normed composition algebra.
Remark. Horizons beyond the exterior model
[meinrenken2013clifford, Section 3.2.4, Theorem 3.3, pp. 59--60];
[kostant1997clifford, Section 2.4, Theorem 8, pp. 286--287];
[lawson2016spin, I.2, pp. 13--19] [fcap-0017]AGENTDRAFTED
Remark. Horizons beyond the exterior model
[meinrenken2013clifford, Section 3.2.4, Theorem 3.3, pp. 59--60];
[kostant1997clifford, Section 2.4, Theorem 8, pp. 286--287];
[lawson2016spin, I.2, pp. 13--19] [fcap-0017]AGENTDRAFTED
The exterior model now has two distinct faithful-range results. In even split dimension, Theorem [fcap-002V] constructs all matrix units, identifies the two even endomorphism blocks, and records irreducibility after restriction to Spin under its separably closed, positive-rank hypotheses. In odd complex dimension, Proposition [fcap-002W] shows that either full Clifford action selects one simple summand, while its restriction to the even algebra is faithful and its actual Spin action exchanges exterior parity in positive rank. Thus exterior parity is not a decomposition into odd-dimensional Spin submodules.
The occupation lines of Theorem [fcap-0025] have also been joined to root and highest-weight theory. The type-D calculation in Proposition [fcap-002X] and Theorem [fcap-002Y] fixes a Borel, proves positive-nilradical generation, and identifies the two fork modules. The type-B calculation in Theorem [fcap-002Z] adds the short root and its irreducible spin module, while Proposition [fcap-0030] derives the finite type-B and type-D characters on the actual Spin torus. The selected TauCeti declarations formalize the Clifford root actions, annihilation identities, and weight vectors. The complex Borel, scalar-extension, irreducibility, torus-descent, and character conclusions are the mathematical arguments in these notes, not one packaged formal theorem.
The low-dimensional complex group comparisons are explicit in Proposition [fcap-0031], Proposition [fcap-0032], Proposition [fcap-0033], and Proposition [fcap-0034]: they identify the actual Spin carriers in dimensions three through six and the stated standard or half-spin modules. These group inverses and module intertwiners are separate from the real algebra classification in Remark [fcap-0016] and its signature-\((1,3)\) instance in Example [fcap-0026]. The concrete real differential comparison in Proposition [fcap-0037] realizes Spin as a closed Lie subgroup, identifies its tangent algebra with the quadratic Clifford lift, and differentiates the vector and finite-dimensional Clifford-module actions; Example [fcap-0038] fixes the planar half-angle normalization. The selected TauCeti declarations formalize the algebraic lift and generator action, while the Lie-group, exponential, and tangent conclusions are the source-grounded arguments in those cards. The based-root calculation in Proposition [fcap-003B] fixes the permutation of the three eight-dimensional highest-weight classes. The actual compact-group lifts and kernel calculation in Theorem [fcap-003C] prove \(\operatorname {Out}_{\mathrm {Lie}}(\operatorname {Spin}_8)\simeq S_3\), while Proposition [fcap-003D] constructs the invariant vector--half-spin trilinear and proves its multiplicity-one uniqueness. The pinned tripled-carrier automorphism is formal context on its stated carrier; it is not used as a packaged theorem about the actual Spin group.
Hyperbolic recurrence, real signatures and quaternary centers [fcap-0010]AGENTDRAFTED
Hyperbolic recurrence, real signatures and quaternary centers [fcap-0010]AGENTDRAFTED
A positive and a negative generator form a hyperbolic plane. Adjoining that plane tensors the Clifford algebra with two-by-two real matrices. Iteration removes the common part of a real signature, while a sign switch gives a complementary one-sided recurrence. With the quaternion and eight-step recurrences, these steps yield the residue-indexed real algebra classification. In dimension three, an even algebra model becomes a group model only after reverse norm one is shown to imply membership in the vector-generated Spin carrier. For the compact and split real signatures this yields the unit Hamilton quaternions and \(SL_2(\mathbb R)\), respectively. The same carrier question in dimension four is settled by a reversal-fixed odd-degree argument. It upgrades the compact even algebra to a pair of unit-quaternion groups and the Lorentz even algebra to \(SL_2(\mathbb C)\), while their centers retain the split and nonsplit signature distinction. Over any field of characteristic different from two, the four-dimensional discriminant center similarly determines a product of two quaternion norm-one groups or one such group over a quadratic field. The compact vector actions become quaternion conjugation in dimension three and left and inverse-right multiplication in dimension four, with explicit coordinates relating these two descriptions. For the split real signatures, symmetric matrices give the action in dimension three, and a pair of real matrix groups acts by left and inverse-right multiplication in dimension four. The compact quaternion action also has a concrete special unitary matrix realization. The Lorentz action becomes congruence on Hermitian matrices, with an explicit sign and coordinate dictionary between the two Lorentz signatures. In dimension five, a central volume term survives reversal; the scalar-square equation eliminates it. In dimension six, a scalar plus a volume element instead supplies an even unit of reverse norm one that does not preserve vectors. These calculations explain the precise limit of the carrier shortcut. The real Pin and Spin groups otherwise follow a separate branch through the double-cover theory.
§ [ca-0001]
Convention. Real signature and Clifford signs [chevalley1954algebraic, II.2.9, pp. 65--66] [fcap-0011]
L∃∀NAGENTDRAFTED
Convention. Real signature and Clifford signs [chevalley1954algebraic, II.2.9, pp. 65--66] [fcap-0011]
L∃∀NAGENTDRAFTED
For \(p,q\ge 0\), put \[Q_{p,q}(x)=\sum _{i<p}x_i^2-\sum _{p\le i<p+q}x_i^2\] on \(\mathbb {R}^{p+q}\), and write \(\mathcal {C}\kern -2pt\ell _{p,q}\) for \(\mathcal {C}\kern -2pt\ell (Q_{p,q})\). Thus the first \(p\) Clifford generators square to \(+1\), and the last \(q\) square to \(-1\). This agrees with Chevalley's convention for the quadratic form and with his positive/negative inertia indices.
Lawson--Michelsohn impose \(v^2=-q_{r,s}(v)1\) [lawson2016spin, I.3, Proposition 3.1, p. 21]. This swaps the indices while leaving the mixed \((1,1)\) recurrence unchanged: \[\mathcal {C}\kern -2pt\ell _{p,q}=\mathcal {C}\kern -2pt\ell ^{\mathrm {Lawson}}_{q,p}.\]
Theorem. Witt extension and the regular-subspace interface [fcap-002A]AGENTDRAFTED
Theorem. Witt extension and the regular-subspace interface [fcap-002A]AGENTDRAFTED
Let \(K\) be a field of characteristic different from two, and let \((V,Q)\) and \((V',Q')\) be isometric finite-dimensional nondegenerate quadratic spaces. If \(U\subseteq V\) is any subspace and \(f:U\to V'\) is an injective linear map satisfying \[Q'(f(u))=Q(u),\] then \(f\) extends to an isometry \(\widetilde f:(V,Q)\simeq (V',Q')\). For two subspaces of one quadratic space, the assumption that the ambient spaces are isometric is automatic.
[bourbaki2007algebra, Section 4, no. 3, Theorem 1, pp. 71--72] states the theorem with an arbitrary source subspace. In [serre1973course, Chapter IV, Section 1.5, Theorem 3, pp. 31--32], the proof explains why degeneracy of that subspace is harmless when the ambient form is nondegenerate: a radical vector can be paired with a new vector, enlarging the subspace toward a regular one. The regular case then splits orthogonally and closes by induction.
TauCeti proves a complementary form. For a finite-dimensional quadratic
space over a field with \(2\) invertible, an isometry equivalence between
subspaces \(W,W'\) extends when \(Q|_W\) is nondegenerate; the ambient form
itself may be degenerate
QuadraticMap.IsometryEquiv.exists_extension. It also chooses
an extension and records its value on \(W\)
QuadraticMap.IsometryEquiv.extension
QuadraticMap.IsometryEquiv.extension_apply. These formal
declarations do not prove the arbitrary-subspace statement above.
The distinction is visible inside \(Q_{1,3}\). The block \[A_0=\begin {pmatrix}5/4&3/4\\3/4&5/4\end {pmatrix}\] on the first positive and first negative coordinates, together with the identity on the other two coordinates, defines an ambient isometry \(A\). It satisfies \(A(e_0+e_1)=2(e_0+e_1)\), so its restriction to the null line is an isometry of a degenerate subspace. The classical theorem covers such a line; the regular-subspace formal declaration does not apply because the source restriction is degenerate.
Proposition. A Lorentz frame can be prescribed [fcap-002B]AGENTDRAFTED
Proposition. A Lorentz frame can be prescribed [fcap-002B]AGENTDRAFTED
Let \(V\) be four-dimensional over \(\mathbb R\), and let \(Q\) be a nondegenerate quadratic form with positive and negative indices \((1,3)\). Suppose \[Q(t)=1,\qquad Q(s)=-1,\qquad B_Q(t,s)=0.\] There is an isometry \(e:(\mathbb R^4,Q_{1,3})\simeq (V,Q)\) with \(e(e_0)=t\) and \(e(e_1)=s\). Moreover, \(H=\operatorname {span}(t,s)\) has an orthogonal complement of dimension two on which \(Q\) is negative definite. The sign convention for \(Q_{1,3}\) is the one fixed in Convention [fcap-0011].
Proof.
Proof.
For all \(a,b\in \mathbb R\), polarization gives
\[Q(at+bs)=a^2-b^2.\]
The polar Gram matrix of \(t,s\) is \(\operatorname {diag}(2,-2)\), so they are
independent and \(H\) is regular of inertia \((1,1)\). By
[bourbaki2007algebra, Section 7, no. 2, Theorem 1 and Definition 2, pp. 117--118],
the real law of inertia gives an initial isometry
\(j:(\mathbb R^4,Q_{1,3})\simeq (V,Q)\).
The isometry from \(j(\operatorname {span}(e_0,e_1))\) to \(H\) sending
\(j(e_0)\) to \(t\) and \(j(e_1)\) to \(s\) has regular source, so Witt extension
supplies an ambient isometry \(g\) of \((V,Q)\)
QuadraticMap.IsometryEquiv.exists_extension. Then
\(e=g\circ j\) has the prescribed values.
The orthogonal decomposition has summands \(H\) and \(H^\perp \).
Additivity of the positive and negative indices
QuadraticForm.sigPos_prod
QuadraticForm.sigNeg_prod gives
\[(1,3)=(1,1)+(0,2).\]
Hence \(H^\perp \) is the required negative plane.
The isometry transport in Proposition [fcap-0029] carries the standard first two Clifford generators to this prescribed pair and commutes with the Spin vector action. The hyperbolic split and quaternionic matrix calculation are already in Example [fcap-0026], which yields the abstract model \(\mathcal {C}\kern -2pt\ell (V,Q)\simeq M_2(\mathbb H)\). This does not identify a particular gamma-matrix homomorphism, its kernel, or its image.
Remark. The radical blocks an unqualified extension theorem [fcap-002C]AGENTDRAFTED
Remark. The radical blocks an unqualified extension theorem [fcap-002C]AGENTDRAFTED
For \(Q(a,b,c)=a^2-b^2\) on \(\mathbb R^3\), with \(e_1,e_2,e_3\) the standard coordinate basis, the radical is \(\mathbb R e_3\). The zero-form lines \(\mathbb R e_3\) and \(\mathbb R(e_1+e_2)\) are isometric by \(e_3\mapsto e_1+e_2\), but this map has no ambient isometric extension. Every ambient isometry preserves the radical, whereas \[B_Q(e_1+e_2,e_1)=2,\] so \(e_1+e_2\) is not radical. This example lies outside both guards above: the ambient form is degenerate, and the source line is not regular.
For the projective-geometric-algebra form
\(Q_{\mathrm {PGA}}(a,b,c)=a^2+b^2\), the positive, negative, and radical
dimensions are \((2,0,1)\), with radical \(\mathbb R e_3\). Its radical
quotient is a two-dimensional positive-definite space. Quotienting preserves
the positive and negative indices
QuadraticForm.sigPos_lift_radical
QuadraticForm.sigNeg_lift_radical, but it changes the
quadratic space. It therefore cannot silently replace the original degenerate
Clifford algebra or its motor carrier. Failure of the classical ambient
nondegeneracy hypothesis does not show that extension fails for PGA;
TauCeti's regular-subspace theorem may still apply there.
Definition. The hyperbolic plane [lawson2016spin, I.4, Theorem 4.1 and (4.3), pp. 25--26] [fcap-0012]
L∃∀NAGENTDRAFTED
Definition. The hyperbolic plane [lawson2016spin, I.4, Theorem 4.1 and (4.3), pp. 25--26] [fcap-0012]
L∃∀NAGENTDRAFTED
The real hyperbolic plane is \[H=(\mathbb {R}^2,Q_{1,1}),\qquad Q_{1,1}(s,t)=s^2-t^2.\] Its coordinate generators \(e_+\) and \(e_-\) satisfy \[e_+^2=1,\qquad e_-^2=-1,\qquad e_+e_-=-e_-e_+.\] For every signature, separating the last positive and negative coordinates gives an isometry \[(\mathbb {R}^{p+q+2},Q_{p+1,q+1}) \simeq (\mathbb {R}^{p+q},Q_{p,q})\perp H.\] The coordinate order is fixed: the retained \(p\) positive and \(q\) negative axes form the first factor, and the last positive and last negative axes form \(H\).
Theorem. The hyperbolic matrix recurrence [lawson2016spin, I.4, Theorem 4.1, (4.3), pp. 25--26] [fcap-0013]
L∃∀NAGENTDRAFTED
Theorem. The hyperbolic matrix recurrence [lawson2016spin, I.4, Theorem 4.1, (4.3), pp. 25--26] [fcap-0013]
L∃∀NAGENTDRAFTED
For finite-dimensional quadratic spaces, Lawson--Michelsohn state the signature recurrence \[\mathcal {C}\kern -2pt\ell _{p+1,q+1}\simeq _{\mathbb {R}\text {-alg}} \mathcal {C}\kern -2pt\ell _{p,q}\otimes _{\mathbb {R}}M_2(\mathbb {R}).\] TauCeti extends the recurrence to any real quadratic module \((M,Q)\) and supplies an explicit formula on generators: \[\mathcal {C}\kern -2pt\ell (Q\perp Q_{1,1})\simeq \mathcal {C}\kern -2pt\ell (Q)\otimes _{\mathbb {R}}M_2(\mathbb {R}).\] With \[\sigma _x=\begin {pmatrix}0&1\\1&0\end {pmatrix},\] the equivalence sends a generator \((m,(s,t))\) to \[\iota _Q(m)\otimes \sigma _x +1\otimes \begin {pmatrix}s&t\\-t&-s\end {pmatrix}.\] The first summand squares to \(Q(m)\), the second to \(s^2-t^2\), and the two anticommute. The universal property therefore gives the forward algebra map. In the other direction, the original Clifford algebra and the matrix algebra act through commuting algebra maps on the hyperbolic Clifford algebra; their tensor lift is inverse to the forward map. The two composites are checked on Clifford generators and pure tensors, which is why TauCeti's extension needs no finite-dimensional hypothesis. Chevalley's split-matrix theorem and orthogonal-sum calculation supply the classical structural mechanism [chevalley1954algebraic, II.2.1 and II.2.5, pp. 42--46].
Writing the displayed generator formula as \(f\), its universal extension is summarized by the commuting diagram
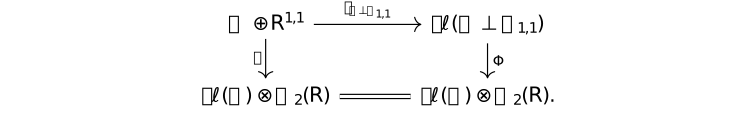
Lemma. Finite hyperbolic reduction [chevalley1954algebraic, II.2.9, pp. 65--66] [fcap-0014]
L∃∀NAGENTDRAFTED
Lemma. Finite hyperbolic reduction [chevalley1954algebraic, II.2.9, pp. 65--66] [fcap-0014]
L∃∀NAGENTDRAFTED
Chevalley splits a finite-dimensional real quadratic space into hyperbolic planes and a definite remainder. TauCeti combines that classical reduction with iteration of Theorem [fcap-0013] and Kronecker equivalences to synthesize the explicit tensor and matrix packaging below. Iterating \(n\) times gives \[\mathcal {C}\kern -2pt\ell _{p+n,q+n}\simeq \mathcal {C}\kern -2pt\ell _{p,q}\otimes _{\mathbb {R}}M_{2^n}(\mathbb {R}).\] Taking \(n=\min (p,q)\) removes the common positive and negative part: \[\mathcal {C}\kern -2pt\ell _{p,q}\simeq \mathcal {C}\kern -2pt\ell _{p-n,q-n}\otimes _{\mathbb {R}}M_{2^n}(\mathbb {R}), \qquad n=\min (p,q).\] Thus if \(p\le q\), the residual algebra is \(\mathcal {C}\kern -2pt\ell _{0,q-p}\); if \(q\le p\), it is \(\mathcal {C}\kern -2pt\ell _{p-q,0}\). The matrix factors combine through the Kronecker equivalence \[M_{2^a}(\mathbb {R})\otimes M_{2^b}(\mathbb {R}) \simeq M_{2^{a+b}}(\mathbb {R}).\] Chevalley supplies the quadratic-space decomposition. The displayed \(M_{2^n}\) packaging and its named equivalences are TauCeti's formalized synthesis.
Theorem. The signature-switch recurrence
[lawson2016spin, I.4, Theorem 4.1 and (4.1), pp. 25--26] [fcap-001X]
L∃∀NAGENTDRAFTED
Theorem. The signature-switch recurrence
[lawson2016spin, I.4, Theorem 4.1 and (4.1), pp. 25--26] [fcap-001X]
L∃∀NAGENTDRAFTED
With the TauCeti signature convention of Convention [fcap-0011], there is an algebra equivalence \[\mathcal {C}\kern -2pt\ell _{p+2,q}\simeq _{\mathbb R\text {-alg}} \mathcal {C}\kern -2pt\ell _{q,p}\otimes _{\mathbb R}M_2(\mathbb R).\] The construction first separates the last positive coordinate from \(Q_{p+2,q}\). Adjoining that positive line permits a Clifford sign switch; negating \(Q_{p+1,q}\) exchanges its positive and negative coordinate blocks. The resulting form is \(Q_{q+1,p+1}\), to which the hyperbolic recurrence of Theorem [fcap-0013] applies.
The accompanying generator theorem
SignatureSwitchRecurrenceEquiv_ι
records this composition through the positive-coordinate splitter, the
sign-switch isometry, and the generator formula for the hyperbolic
equivalence. It fixes the equivalence on the canonical Clifford generators
rather than asserting only that some algebra isomorphism exists.
After converting between the two signature conventions, inverting Lawson--Michelsohn's equation (4.1), using \(\mathcal {C}\kern -2pt\ell ^{\mathrm {Lawson}}_{0,2}\cong M_2(\mathbb R)\), and swapping the indices yields the displayed algebra isomorphism. Their equation (4.3) is instead the mixed \((1,1)\) recurrence used in Theorem [fcap-0013]. Chevalley's split-matrix and orthogonal-sum constructions give the same structural ingredients [chevalley1954algebraic, II.2.1 and II.2.5, pp. 42--46]. The exact splitter composition and generator formula are additional data recorded by TauCeti.
Remark. Why algebraic periodicity is a separate branch
[chevalley1954algebraic, II.2.1, II.2.5, and II.2.9, pp. 42--46, 65--66];
[lawson2016spin, I.4, Theorems 4.1 and 4.3, pp. 25--29] [fcap-001Y]AGENTDRAFTED
Remark. Why algebraic periodicity is a separate branch
[chevalley1954algebraic, II.2.1, II.2.5, and II.2.9, pp. 42--46, 65--66];
[lawson2016spin, I.4, Theorems 4.1 and 4.3, pp. 25--29] [fcap-001Y]AGENTDRAFTED
The recurrences in Theorem [fcap-0013], Lemma [fcap-0014], and Theorem [fcap-001X] use Clifford universal properties, orthogonal sums, tensor products, coordinate isometries, and the real base entries. They do not use the Spin representation, the structure theorem obtained from a spinor module, or the Pin and Spin double covers. This is the algebraic branch of Layer 7.
The real groups \(\operatorname {Pin}(p,q)\) and \(\operatorname {Spin}(p,q)\) form a different branch. Their actions, kernels, and algebraic extensions specialize the group theory developed in § [fcap-0007], and therefore genuinely consume the Layer-2 Pin/Spin work. The distinction between these branches is the dependency correction recorded in TauCetiRoadmap PR 225. It changes the order in which the mathematics can be built; it does not turn the roadmap proposal itself into a formal theorem.
Example. Four real Clifford base entries [lawson2016spin, I.4, Theorem 4.3 and Tables I--II, pp. 27--29] [fcap-0015]
Example. Four real Clifford base entries [lawson2016spin, I.4, Theorem 4.3 and Tables I--II, pp. 27--29] [fcap-0015]
With \(\mathcal {C}\kern -2pt\ell _{0,0}\simeq \mathbb {R}\) as the scalar anchor, the signature convention of Convention [fcap-0011] gives four nontrivial base entries:
\[\begin {aligned}
\mathcal {C}\kern -2pt\ell _{0,0}&\simeq \mathbb {R}, &
\mathcal {C}\kern -2pt\ell _{1,0}&\simeq \mathbb {R}\times \mathbb {R}, &
\mathcal {C}\kern -2pt\ell _{0,1}&\simeq \mathbb {C},\\
\mathcal {C}\kern -2pt\ell _{0,2}&\simeq \mathbb {H}, &
\mathcal {C}\kern -2pt\ell _{1,1}&\simeq M_2(\mathbb {R}).
\end {aligned}\]
For \(\mathcal {C}\kern -2pt\ell _{0,2}\), the two negative generators map to the quaternion units
\(i\) and \(j\); their product maps to \(k\). Thus they square to \(-1\) and
anticommute, as required by the Clifford relations. The exact generator map is
recorded by TauCeti.realCliffordZeroTwoEquivQuaternion_ι.
For \(\mathcal {C}\kern -2pt\ell _{1,1}\), the positive and negative generators may be represented by \[e_+\longmapsto \begin {pmatrix}1&0\\0&-1\end {pmatrix}, \qquad e_-\longmapsto \begin {pmatrix}0&1\\-1&0\end {pmatrix}.\] Their squares are \(+I\) and \(-I\), and they anticommute. The last equivalence is also the case \(p=q=0\) of Theorem [fcap-0013]. The index swap in Convention [fcap-0011] explains why Lawson's one-generator table lists \(\mathbb {C}\) and \(\mathbb {R}\times \mathbb {R}\) in the opposite order.
Lemma. Reverse norm one is the Spin carrier in real dimension three [fcap-002G]AGENTDRAFTED
Lemma. Reverse norm one is the Spin carrier in real dimension three [fcap-002G]AGENTDRAFTED
Let \(V\) be a three-dimensional real vector space and let \(Q\) be
nondegenerate. Suppress the canonical generator map in Clifford products.
For \(x\in \mathcal {C}\kern -2pt\ell ^{+}(Q)\), the following are equivalent:
\[x\text { is the Clifford value of an element of }\operatorname {Spin}(Q),
\qquad \operatorname {rev}(x)x=1.\]
The forward implication is the even-unitary condition
CliffordAlgebra.evenUnitaryGroup.mem_iff_reverse_mul_self_eq_one
CliffordAlgebra.range_spinGroup_toUnits.
For the converse, the scalar--bivector decomposition in dimension three
writes \(x=a+Z\). Every nonzero bivector is decomposable. If \(Z\ne 0\), let
\(P\) be its supporting two-plane. The plane contains \(u\) with \(Q(u)\ne 0\):
otherwise polarization would give \(P\subseteq P^\perp \), impossible because
\(\dim P=2\) and nondegeneracy gives \(\dim P^\perp =1\). Since
\(\bigwedge ^2P\) is one-dimensional, choose \(w\in P\) so that
\(Z=\beta _Q(u,w)\). If \(Z=0\), choose any nonisotropic \(u\) and take \(w=0\).
Using the unhalved polar form from Convention [fcap-0027],
\[\beta _Q(u,w)=uw-\frac 12B_Q(u,w),\qquad
v:=ux=\left (a-\frac 12B_Q(u,w)\right )u+Q(u)w.\]
Thus \(v\) is a vector. Reversal and the norm-one equation give
\[Q(v)1=\operatorname {rev}(v)v
=\operatorname {rev}(x)uux
=Q(u)\operatorname {rev}(x)x=Q(u)1.\]
The real scalar map is injective, so \(Q(v)=Q(u)\ne 0\). Consequently
\[x=\left (\frac {u}{Q(u)}\right )v,
\qquad Q\left (\frac {u}{Q(u)}\right )Q(v)=1.\]
This is a product of two actual nonisotropic vectors, and TauCeti's pair
criterion places it in Spin
CliffordAlgebra.ι_mul_ι_mem_spinGroup_of_norm_mul_norm_eq_one.
The proof includes the scalar case \(Z=0\); it uses neither a normalizer
characterization nor a connectedness argument. The general distinction
between reverse norm one and Lipschitz membership remains the one recorded in
Remark [fcap-0028].
Example. The compact three-dimensional Spin group is the unit quaternions [fcap-002H]AGENTDRAFTED
Example. The compact three-dimensional Spin group is the unit quaternions [fcap-002H]AGENTDRAFTED
Let \(Q_{3,0}(x_0,x_1,x_2)=x_0^2+x_1^2+x_2^2\) and write \(e_0,e_1,e_2\)
for its coordinate basis. TauCeti's chosen algebra equivalence
\(\theta :\mathcal {C}\kern -2pt\ell ^{+}(Q_{3,0})\simeq \mathbb H\) has the exact axes
\[e_0e_1\longmapsto -k,\qquad
e_0e_2\longmapsto i,\qquad
e_1e_2\longmapsto j\]
TauCeti.realCliffordThreeZeroEvenEquivQuaternion
TauCeti.realCliffordThreeZeroEvenEquivQuaternion_ι_single_zero_one
TauCeti.realCliffordThreeZeroEvenEquivQuaternion_ι_single_two_zero
TauCeti.realCliffordThreeZeroEvenEquivQuaternion_ι_single_one_two.
Hence
\[\theta (s+A e_0e_1+B e_0e_2+C e_1e_2)
=s+B i+C j-A k.\]
Under \(\theta \), reversal is quaternion conjugation and reverse norm is
\[s^2+A^2+B^2+C^2\]
TauCeti.realCliffordThreeZeroEvenEquivQuaternion_reverseEven
TauCeti.realCliffordThreeZeroEvenEquivQuaternion_map_reverseEven_mul_self_eq_normSq.
Let \(\mathbb H^1=\{q\in \mathbb H:\bar q q=1\}\). Restricting \(\theta \)
to Spin gives a homomorphism
\[\operatorname {Spin}(Q_{3,0})\longrightarrow \mathbb H^1.\]
For \(q=r+x i+y j+z k\in \mathbb H^1\), the inverse Clifford value is
\[r-z e_0e_1+x e_0e_2+y e_1e_2.\]
Its reverse norm is one, so the dimension-three carrier lemma places it in
the actual Spin group. The algebra inverse proves both compositions and
multiplicativity. Therefore
\[\operatorname {Spin}(Q_{3,0})\simeq \mathbb H^1.\]
TauCeti separately packages the algebra map as an equivalence between the
even-unitary carrier and unit quaternions
TauCeti.realCliffordThreeZeroEvenUnitaryEquivQuaternionUnitary;
the preceding carrier lemma is what identifies that carrier with Spin in
this real dimension-three case.
In [gallier2014clifford, Section 1.4, pp. 28--29], the analogous compact calculation writes the even element, obtains its sum-of-four-squares norm, and identifies the unit quaternions. Its generators square to \(-1\). Likewise, [lawson2016spin, I.3, Theorem 3.7, pp. 23--24; I.4, (4.0), p. 25] uses \(v^2=-q(v)\) to reduce an even algebra and identify the quaternion base entry. Translating by \(Q=-q\) and the even sign-change equivalence gives the same compact algebra and norm. The displayed axis signs are the exact TauCeti choice above, rather than a relabeling imported from either source.
Example. The compact three-dimensional Spin action is quaternion conjugation [fcap-003J]AGENTDRAFTED
- October 8, 2026
Example. The compact three-dimensional Spin action is quaternion conjugation [fcap-003J]AGENTDRAFTED
- October 8, 2026
For \(Q_{3,0}=x_0^2+x_1^2+x_2^2\), use the algebra map
\(\theta :\mathcal {C}\kern -2pt\ell ^+(Q_{3,0})\simeq \mathbb H\) of Example [fcap-002H].
The vector isometry to pure quaternions is
\[\eta _3(v_0e_0+v_1e_1+v_2e_2)=-v_1i+v_0j-v_2k.\]
For \(s\in \operatorname {Spin}(Q_{3,0})\) and \(q=\theta (s)\in \mathbb H^1\), the
ordinary Clifford conjugation action satisfies
\[\eta _3(svs^{-1})=q\eta _3(v)\bar q.\]
These are the coordinates and action in TauCeti
TauCeti.coe_realCliffordThreeZeroPureQuaternionEquiv_apply
TauCeti.realSpinThreeEquivQuaternionUnitary_action.
The volume element \(\omega =e_0e_1e_2\) is central and has \(\omega ^2=-1\). Multiplying a vector by it gives \[v\omega =v_0e_1e_2+v_1e_2e_0+v_2e_0e_1,\qquad \eta _3(v)=\theta (v\omega ).\] The three coefficients are only permuted and signed, so \(\eta _3\) is an isometry onto the pure quaternions. Since \(\omega \) is central, \[(svs^{-1})\omega =s(v\omega )s^{-1}.\] Apply \(\theta \); reversal on the even algebra becomes quaternion conjugation, and \(q^{-1}=\bar q\). This proves the displayed action formula.
The axes also determine the sign of the rotation. For real \(t\), put \(s=\cos t+\sin t\,e_0e_1\). Its reverse norm is one, hence it belongs to Spin by Example [fcap-002H], and \(q=\cos t-\sin t\,k\). Direct multiplication gives \[\begin {aligned} se_0s^{-1}&=\cos (2t)e_0-\sin (2t)e_1,\\ se_1s^{-1}&=\sin (2t)e_0+\cos (2t)e_1,\\ se_2s^{-1}&=e_2. \end {aligned}\] In quaternion coordinates the first identity is \(qj\bar q=\cos (2t)j+\sin (2t)i\), since \(\eta _3(e_1)=-i\). Thus the rotor parameter is a half-angle with the orientation fixed by the stated Clifford and quaternion axes.
Gallier [gallier2014clifford, Section 1.4, p. 29] proves the same volume-element transport to quaternion conjugation with compact generators of square \(-1\). His volume has square \(+1\), and his map is \(v\mapsto -\omega v\); for the positive squares here it is \(v\mapsto v\omega \), followed by the axes of Example [fcap-002H]. Porteous [porteous1995clifford, Chapter 8, Propositions 8.19--8.21, pp. 62--63] describes the resulting unit-quaternion rotations of pure quaternions. The signed half-angle calculation above specifies this action in the coordinates used here.
Example. The split three-dimensional Spin group is \(SL_2(\mathbb R)\) [fcap-002I]AGENTDRAFTED
Example. The split three-dimensional Spin group is \(SL_2(\mathbb R)\) [fcap-002I]AGENTDRAFTED
For \(Q_{2,1}(x_0,x_1,x_2)=x_0^2+x_1^2-x_2^2\), set
\(A=e_0e_1\), \(B=e_0e_2\), and \(C=e_1e_2\). Then
\[A^2=-1,\qquad B^2=C^2=1,\qquad AB=-C.\]
The assignments
\[A\longmapsto \begin {pmatrix}0&1\\-1&0\end {pmatrix},\qquad
B\longmapsto \begin {pmatrix}0&1\\1&0\end {pmatrix},\qquad
C\longmapsto \begin {pmatrix}-1&0\\0&1\end {pmatrix}\]
satisfy these relations, and the images of \(1,A,B,C\) form a basis of
\(M_2(\mathbb R)\). They therefore define an algebra equivalence \(\Phi \) with
\[\Phi (s+aA+bB+cC)=
\begin {pmatrix}s-c&a+b\\-a+b&s+c\end {pmatrix}.\]
Reversal negates \(A,B,C\), so it becomes matrix adjugation, and
\[N_{\mathrm {rev}}(s+aA+bB+cC)
=s^2+a^2-b^2-c^2=\det \Phi (s+aA+bB+cC)\]
CliffordAlgebra.map_reverseEven_eq_adjugate_of_finrank_eq_three
CliffordAlgebra.reverseEven_mul_eq_one_iff_det_eq_one_of_finrank_eq_three.
Restriction gives \(\operatorname {Spin}(Q_{2,1})\to SL_2(\mathbb R)\). Conversely, if \(M=(m_{ij})\in SL_2(\mathbb R)\), put \[\begin {aligned} s&=\frac {m_{00}+m_{11}}2,& a&=\frac {m_{01}-m_{10}}2,\\ b&=\frac {m_{01}+m_{10}}2,& c&=\frac {m_{11}-m_{00}}2. \end {aligned}\] Then \(\Phi (s+aA+bB+cC)=M\), and its reverse norm is \(\det M=1\). The carrier lemma puts this inverse value in the actual Spin group; the algebra maps give two-sided multiplicative inverses. Thus \[\operatorname {Spin}(Q_{2,1})\simeq SL_2(\mathbb R).\]
The source translation matters. Lawson--Michelsohn's convention turns this even algebra into \(\operatorname {Cl}_{0,2}\simeq M_2(\mathbb R)\) via [lawson2016spin, I.3, Theorem 3.7, pp. 23--24; I.4, (4.0), p. 25]. With the reversed index convention, [gallier2014clifford, Example 1.3, p. 33] independently records \(\operatorname {Cl}_{2,0}\simeq M_2(\mathbb R)\), the same real matrix base algebra. Their indefinite Pin/Spin carrier conventions allow factors of quadratic value \(\pm 1\) [lawson2016spin, I.2, (2.24)--(2.25), p. 18] [gallier2014clifford, Section 1.5, Definition 1.6, p. 31]. We use their algebra identifications but impose the displayed reverse-norm-one equation. For example, \(e_0e_2\) has reverse norm \(-1\) and maps to a determinant \(-1\) matrix, so it is excluded here.
This split form has polarization
\(W=\mathbb R(e_0+e_2)\),
\(W'=\mathbb R((e_0-e_2)/4)\), and line \(\mathbb R e_1\): the unhalved polar
pairing of the displayed generators is \(1\), and the line coordinate squares
to \(Q_{2,1}\). TauCeti's polarized dimension-three theorem therefore gives
an independent abstract group equivalence with \(SL_2(\mathbb R)\)
TauCeti.exists_spinGroup_mulEquiv_specialLinearGroup_and_spinRep_equiv_stdSLRep_of_finrank_eq_three.
The concrete map \(\Phi \) above is not asserted to be definitionally that map,
and the theorem's representation refinement belongs to the later module
packet. Likewise, the vector-action image is the spinor-norm kernel from
Theorem [fcap-0023], not all of \(SO(2,1)\). No component or covering-space claim
is made.
Example. The split three-dimensional Spin action is symmetric matrix congruence [fcap-003X]AGENTDRAFTED
Example. The split three-dimensional Spin action is symmetric matrix congruence [fcap-003X]AGENTDRAFTED
For \(Q_{2,1}(v)=v_0^2+v_1^2-v_2^2\), keep the algebra map
\(\Phi :\mathcal {C}\kern -2pt\ell ^+(Q_{2,1})\simeq M_2(\mathbb R)\) of Example [fcap-002I].
Multiplication by the last generator gives symmetric matrix coordinates
\[X(v)=\Phi (ve_2)=
\begin {pmatrix}-v_2-v_1&v_0\\v_0&-v_2+v_1\end {pmatrix},
\qquad \det X(v)=-Q_{2,1}(v).\]
The inverse sends \(\begin {pmatrix}a&b\\b&d\end {pmatrix}\) to
\((b,(d-a)/2,-(a+d)/2)\). Thus \(X\) is a real linear equivalence onto
the symmetric matrices, with the stated negative determinant form
TauCeti.coe_realCliffordTwoOneVectorEquivSymmetric_apply
TauCeti.realCliffordTwoOneVectorEquivSymmetric_det.
For \(s\in \operatorname {Spin}(Q_{2,1})\) and \(M=\Phi (s)\in SL_2(\mathbb R)\),
the vector action becomes
\[X(svs^{-1})=M X(v)M^{\mathsf T}.\]
To prove the formula, write \(A=e_0e_1\), \(B=e_0e_2\), and
\(C=e_1e_2\). Since \(e_2^2=-1\), conjugation by \(e_2\) is
\(\gamma (x)=-e_2xe_2\). It fixes \(A\) and negates \(B,C\).
On their three matrices in Example [fcap-002I], and on the identity, this gives
\[\Phi (\gamma (x))=\operatorname {adj}(\Phi (x))^{\mathsf T}.\]
Both sides are linear in \(x\), so the basis check proves the equality
on the whole even algebra. Moreover,
\[(svs^{-1})e_2=s(ve_2)\gamma (s^{-1}).\]
The determinant-one equation gives
\(\operatorname {adj}(M^{-1})=M\); applying \(\Phi \) proves the action.
TauCeti's bilinear-generator formula sends \(A,B,C\) to exactly these
three matrices, so its group map and action use this same \(\Phi \)
TauCeti.realCliffordTwoOneEvenEquivMatrix_ι
TauCeti.realSpinTwoOneEquivSpecialLinear_action.
For example, let \(M=\operatorname {diag}(a,a^{-1})\) with \(a>0\), and choose its Spin preimage using Example [fcap-002I]. Put \(c=(a^2+a^{-2})/2\) and \(h=(a^2-a^{-2})/2\). The congruence action is \[v_0'=v_0,\qquad v_1'=cv_1+hv_2,\qquad v_2'=hv_1+cv_2.\] Here \(c^2-h^2=1\). The two null coordinates \(v_1+v_2\) and \(v_1-v_2\) are multiplied by \(a^2\) and \(a^{-2}\), respectively. This exhibits the action on both null directions in the chosen coordinates.
For comparison, the compact quaternion action of Example [fcap-003J]
has a complex matrix realization. Distinguish quaternion units
\(\mathbf i,\mathbf j,\mathbf k\) from the complex scalar \(i\). The map
\[\iota (a+b\mathbf i+c\mathbf j+d\mathbf k)=
\begin {pmatrix}a+ib&c+id\\-c+id&a-ib\end {pmatrix}\]
preserves multiplication and sends quaternion conjugation to conjugate
transpose. Its determinant is \(a^2+b^2+c^2+d^2\), so it identifies the
unit quaternions with \(SU(2)\). Indeed a special unitary matrix has the
form \(\begin {pmatrix}z&w\\-\bar w&\bar z\end {pmatrix}\) with
\(|z|^2+|w|^2=1\), which recovers the four real coordinates. These are
Gallier's axes [gallier2014clifford, Section 1.1, pp. 8--9], and
the exact embedding and group equivalence in TauCeti
Quaternion.toComplexMatrix
Quaternion.unitaryEquivSpecialUnitaryGroup.
Keep \(\eta _3(v)=-v_1\mathbf i+v_0\mathbf j-v_2\mathbf k\)
from Example [fcap-003J], and put \(K(v)=i\iota (\eta _3(v))\).
It is a traceless Hermitian matrix. Applying \(i\iota \) to the already
proved quaternion action gives
\[K(svs^{-1})=U K(v)U^*,\qquad U=\iota (\theta (s))\in SU(2),\]
where \(U^*\) is conjugate transpose. The composite Spin-to-\(SU(2)\)
isomorphism is available in TauCeti
TauCeti.realSpinThreeEquivSpecialUnitary.
Its action theorem uses the unscaled matrix \(\iota (\eta _3(v))\)
TauCeti.realSpinThreeEquivSpecialUnitary_action;
multiplication by the central scalar \(i\) gives the displayed \(K\) formula.
Thus neither quaternion nor vector axes change. The split formula uses
real symmetric matrices and \(SL_2(\mathbb R)\) instead. The
fixed-vector transport underlying these formulas is illustrated by
[porteous1995clifford, Chapter 16, Proposition 16.9, pp. 143--144].
For the indefinite vector-action image, retain the spinor-norm kernel
of Theorem [fcap-0023]; no component or covering-space assertion is needed.
Lemma. Reverse norm one is the Spin carrier in real dimension four [fcap-002J]AGENTDRAFTED
Lemma. Reverse norm one is the Spin carrier in real dimension four [fcap-002J]AGENTDRAFTED
Let \(V\) be a four-dimensional real vector space and let \(Q\) be
nondegenerate. Suppress the canonical generator map in Clifford products.
For \(x\in \mathcal {C}\kern -2pt\ell ^{+}(Q)\), the following are equivalent:
\[x\text { is the Clifford value of an element of }\operatorname {Spin}(Q),
\qquad \operatorname {rev}(x)x=1.\]
The forward implication follows from the exact Spin-carrier description
CliffordAlgebra.range_spinGroup_toUnits.
Conversely, suppose \(\operatorname {rev}(x)x=1\). Since the Clifford algebra is finite-dimensional, the displayed left inverse is also a right inverse, so \(x\) is a unit and \(x^{-1}=\operatorname {rev}(x)\). For \(v\in V\), put \(w=xvx^{-1}\). The element \(w\) is odd, and \[\operatorname {rev}(w) =\operatorname {rev}(x^{-1})v\operatorname {rev}(x) =xvx^{-1}=w.\] In an orthogonal-basis Clifford expansion in dimension four, the odd part has only degrees one and three. Reversal is \(+1\) on degree one and \(-1\) on degree three, so \(w\in V\). Gallier uses this observation in the compact calculation [gallier2014clifford, p. 30]; the same basis-and-reversal argument applies to every nondegenerate real form in dimension four. Also \(w^2=Q(v)1\). Conjugation is injective, and its restriction to the finite-dimensional space \(V\) is therefore an automorphism. Thus it defines \(g\in O(V,Q)\).
Choose \(y\) in the vector-generated Lipschitz group whose twisted action
is \(g\)
CliffordAlgebra.lipschitzToOrthogonal_surjective, and set
\(z=y^{-1}x\). Since \(x\) is even, equality of the two actions rearranges for
the grading involution \(\alpha \) to
\[\alpha (z)v=vz\qquad (v\in V).\]
The graded-centrality theorem therefore gives \(z=c1\) for some real \(c\)
CliffordAlgebra.exists_eq_algebraMap_of_involute_mul_ι_eq_ι_mul.
The unit \(z\) has \(c\ne 0\). Nondegeneracy and positive dimension supply a
nonisotropic vector, so every nonzero scalar unit belongs to the generated
Lipschitz group
CliffordAlgebra.unitsMap_algebraMap_mem_lipschitzGroup.
Thus \(x=yz\) is Lipschitz. It is even and has reverse norm one, hence lies in
Spin by Remark [fcap-0028]. This dimension-sensitive argument is not asserted in
dimension five or six.
Example. The compact four-dimensional Spin group is a pair of unit quaternions [fcap-002K]AGENTDRAFTED
Example. The compact four-dimensional Spin group is a pair of unit quaternions [fcap-002K]AGENTDRAFTED
For \(Q_{4,0}=x_0^2+x_1^2+x_2^2+x_3^2\), let
\(I=e_0e_1e_2e_3\). Then \(I^2=1\), \(\operatorname {rev}(I)=I\), and \(I\)
commutes with the even algebra
CliffordAlgebra.prod_map_ι_sq_scalar
CliffordAlgebra.prod_map_ι_mul_ι_of_even_length.
Let \(H_0\) be the quaternion subalgebra with basis
\(1,e_0e_1,e_0e_2,e_1e_2\), and choose
\(\theta _0:H_0\simeq \mathbb H\) with the quaternion axes of
Example [fcap-002H]:
\[e_0e_1\longmapsto -k,\qquad
e_0e_2\longmapsto i,\qquad
e_1e_2\longmapsto j.\]
The eight even basis monomials show uniquely that every even value is
\(u+Iv\) with \(u,v\in H_0\). Centrality and \(I^2=1\) make
\[\Phi (u+Iv)
=\bigl (\theta _0(u)+\theta _0(v),\theta _0(u)-\theta _0(v)\bigr )\]
an algebra map. Its inverse is
\[(q_+,q_-)
\longmapsto
\theta _0^{-1}\left (\frac {q_++q_-}{2}\right )
+I\theta _0^{-1}\left (\frac {q_+-q_-}{2}\right ).\]
These formulas prove both multiplicativity and bijectivity.
Reversal becomes quaternion conjugation in each factor. If \(\mathbb H^1=\{q\in \mathbb H:\bar q q=1\}\) and \(\Phi (x)=(q_+,q_-)\), then \[\Phi (\operatorname {rev}(x)x) =(\bar q_+q_+,\bar q_-q_-),\qquad \operatorname {Spin}(Q_{4,0})\simeq \mathbb H^1\times \mathbb H^1.\] The forward restriction lands in the displayed product. Conversely, the written algebra inverse sends a pair of unit quaternions to an even unit of reverse norm one, and the dimension-four carrier lemma places it in the actual Spin group. No connectedness or covering-space argument is used.
Gallier computes the same \(u+Iv\mapsto (u+v,u-v)\) decomposition, norm equations, and compact group product using negative-square compact generators [gallier2014clifford, pp. 29--30]. Lawson--Michelsohn independently give the compact even-algebra reduction [lawson2016spin, I.3, Theorem 3.7, pp. 23--24] and the \(\mathbb H\oplus \mathbb H\) entry [lawson2016spin, I.4, Table I, p. 28]. Their relation \(v^2=-q(v)\) and the index translation of Convention [fcap-0011] account for the sign change. The axis labels above are those fixed in Example [fcap-002H], not labels imported from either source. Finally, \((1\pm I)/2\) are the two nonzero complementary central idempotents, so the even center is the split algebra \(\mathbb R\oplus \mathbb R\).
Example. The compact four-dimensional Spin action is left and right quaternion multiplication [fcap-003K]AGENTDRAFTED
Example. The compact four-dimensional Spin action is left and right quaternion multiplication [fcap-003K]AGENTDRAFTED
For \(Q_{4,0}=x_0^2+x_1^2+x_2^2+x_3^2\), keep the algebra map \(\Phi :\mathcal {C}\kern -2pt\ell ^+(Q_{4,0})\simeq \mathbb H\times \mathbb H\) of Example [fcap-002K]. Write \(\Phi (s)=(q_+,q_-)\) for \(s\in \operatorname {Spin}(Q_{4,0})\). In the quaternion coordinates \[W(v_0e_0+v_1e_1+v_2e_2+v_3e_3)=-v_3-v_1i+v_0j-v_2k,\] the vector action is \[W(svs^{-1})=q_+W(v)\bar q_-.\] The signed permutation \(W\) identifies the Euclidean vector norm with the quaternion norm. Both factors are unit quaternions, so the right multiplier is the inverse of \(q_-\).
To prove the formula, let \(I=e_0e_1e_2e_3\) and use the quaternion subalgebra \(H_0\) from Example [fcap-002K]. The vector \(e_3\) commutes with \(H_0\) and anticommutes with \(I\). Hence \(C(x)=e_3xe_3\) interchanges the two components of \(\Phi (x)\). The identities \[e_0e_3=-I e_1e_2,\qquad e_1e_3=I e_0e_2,\qquad e_2e_3=-I e_0e_1\] give \(\Phi _1(ve_3)=-W(v)\). Now \[(svs^{-1})e_3=s(ve_3)C(s^{-1}).\] Applying \(\Phi _1\) and negating proves the action formula. For the diagonal pair \((q,q)\), the vector \(e_3\) is fixed because \(W(e_3)=-1\); on its orthogonal complement \(W\) restricts to \(\eta _3\) of Example [fcap-003J]. Thus the three-dimensional conjugation action is the diagonal case.
TauCeti chooses a different algebra equivalence, denoted here by
\(\widehat \Phi \). Its bilinear-generator formula gives
\[\begin {aligned}
e_0e_1&\longmapsto (-k,-k),& e_0e_2&\longmapsto (j,-j),\\
e_0e_3&\longmapsto (i,i),& e_1e_2&\longmapsto (-i,i),\\
e_1e_3&\longmapsto (j,j),& e_2e_3&\longmapsto (k,-k)
\end {aligned}\]
TauCeti.realCliffordFourZeroEvenEquivQuaternionProd_ι.
In particular, \(\widehat \Phi (I)=(1,-1)\). Define quaternion automorphisms
\[\begin {aligned}
A(a+bi+cj+dk)&=a-ci+bj+dk,\\
B(a+bi+cj+dk)&=a+ci-bj+dk.
\end {aligned}\]
They are conjugation by \((1+k)/\sqrt {2}\) and \((1-k)/\sqrt {2}\),
respectively, and satisfy \(B(q)=kA(q)k^{-1}\). The rows for
\(e_0e_1,e_0e_2,e_1e_2\) identify the restrictions to \(H_0\) as
\(A\circ \theta _0\) and \(B\circ \theta _0\). Together with the image of
\(I\), the decomposition \(x=u+Iu'\) therefore proves
\[\widehat \Phi (x)=\bigl (A(\Phi _1(x)),B(\Phi _2(x))\bigr ).\]
TauCeti's vector coordinates are
\[\eta _4(v)=-v_2+v_1i-v_0j+v_3k=A(W(v))k^{-1}\]
TauCeti.realCliffordFourZeroQuaternionEquiv_apply.
Since \(A,B\) commute with quaternion conjugation and
\(A(\bar q)k^{-1}=k^{-1}\overline {B(q)}\), the formula for \(W\) gives
\[\eta _4(svs^{-1})=A(q_+)\eta _4(v)\overline {B(q_-)}.\]
This is precisely the action in the \(\widehat \Phi \) coordinates
TauCeti.realSpinFourEquivQuaternionUnitaryProd_action.
The displayed changes of coordinates derive its relation to the natural
pair \(\Phi \) used in Example [fcap-002K].
Gallier [gallier2014clifford, Section 1.4, pp. 29--30] gives the compact even-algebra decomposition into two quaternion factors with negative-square generators; Example [fcap-002K] uses the positive-square convention. Porteous [porteous1995clifford, Chapter 8, Propositions 8.26--8.27, p. 65] describes the four-dimensional rotations \(z\mapsto qz\bar r\) for unit quaternions \(q,r\). The calculation with \(ve_3\) identifies these left and inverse-right factors for \(\Phi \); the explicit \(A,B,W,\eta _4\) formulas then give the coordinate translation to \(\widehat \Phi \).
Example. The split four-dimensional Spin action is left and inverse-right multiplication [fcap-003Y]AGENTDRAFTED
Example. The split four-dimensional Spin action is left and inverse-right multiplication [fcap-003Y]AGENTDRAFTED
For \(Q_{2,2}(v)=v_0^2+v_1^2-v_2^2-v_3^2\), the even Clifford algebra is a pair of real matrix algebras. We construct its coordinates to specify which Spin factor acts on each side of a vector. Set \(A=e_0e_1\), \(B=e_0e_2\), \(C=e_1e_2\), and \(I=e_0e_1e_2e_3\). The subalgebra \(H_0=\langle 1,A,B,C\rangle _{\mathbb R}\) has \(A^2=-1\), \(B^2=C^2=1\), and \(AB=-C\). Define \[J=\begin {pmatrix}0&1\\-1&0\end {pmatrix},\quad S=\begin {pmatrix}0&1\\1&0\end {pmatrix},\quad D=\begin {pmatrix}-1&0\\0&1\end {pmatrix}.\] The assignments \(\rho (A)=-J\), \(\rho (B)=D\), \(\rho (C)=S\) satisfy these relations and give a basis of \(M_2(\mathbb R)\) together with the identity. They define an algebra equivalence \(\rho \). The volume element \(I\) is central in the even algebra and \(I^2=1\). The eight even basis monomials give \(\mathcal {C}\kern -2pt\ell ^+(Q_{2,2})=H_0\oplus I H_0\). Hence the map \[\Phi (u+Iw)=\bigl (\rho (u)-\rho (w),\ S(\rho (u)+\rho (w))S\bigr )\] is an algebra equivalence to \(M_2(\mathbb R)\times M_2(\mathbb R)\). For a pair \((P,R)\), its inverse is recovered from \[\rho (u)=\tfrac 12(P+SRS),\qquad \rho (w)=\tfrac 12(SRS-P).\]
The reversion fixes \(I\) and negates \(A,B,C\). On \(H_0\), this is matrix adjugation, since \(\rho (A), \rho (B),\rho (C)\) are traceless. Conjugation by \(S\) commutes with adjugation, so \[\Phi (\operatorname {rev}(x))= \bigl (\operatorname {adj}(\Phi _1(x)), \operatorname {adj}(\Phi _2(x))\bigr ).\] Consequently \(\operatorname {rev}(x)x=1\) if and only if both component determinants are one. The carrier lemma Lemma [fcap-002J] therefore restricts \(\Phi \), with the displayed inverse, to the actual group \[\operatorname {Spin}(Q_{2,2})\simeq SL_2(\mathbb R)\times SL_2(\mathbb R).\] Porteous's norm-one subgroup is denoted \(\operatorname {Spin}^+\); his split-four entry is a pair of \(Sp_2(\mathbb R)\) factors [porteous1995clifford, Chapter 17, Theorem 17.9 and Table 14, p. 159]. In degree two, \(M^{\mathsf T}JM=(\det M)J\), so these are precisely \(SL_2(\mathbb R)\). The norm-one restriction is essential to that comparison.
Our pair map has the following six bivector images:
\[\begin {aligned}
e_0e_1&\longmapsto (-J,J),& e_0e_2&\longmapsto (D,-D),\\
e_0e_3&\longmapsto (-S,S),& e_1e_2&\longmapsto (S,S),\\
e_1e_3&\longmapsto (D,D),& e_2e_3&\longmapsto (-J,-J).
\end {aligned}\]
In particular \(\Phi (I)=(-1,1)\). These are the specializations of
TauCeti's bilinear-generator formula
TauCeti.realCliffordTwoTwoEvenEquivMatrixProd_ι.
Since the bivectors generate the even algebra, this identifies \(\Phi \)
with its concrete even-algebra map and hence identifies the restricted
group equivalence
TauCeti.realSpinTwoTwoEquivSpecialLinearProd.
Now encode vectors by
\[X(v)=\Phi _1(ve_3)S=
\begin {pmatrix}-v_0-v_2&-v_1-v_3\\v_1-v_3&-v_0+v_2\end {pmatrix}.\]
The inverse sends \(\begin {pmatrix}a&b\\c&d\end {pmatrix}\) to
\((-(a+d)/2,(c-b)/2,(d-a)/2,-(b+c)/2)\). A determinant expansion gives
\(\det X(v)=Q_{2,2}(v)\). Thus \(X\) identifies the whole vector space
with the determinant quadratic space of real two-by-two matrices
TauCeti.realCliffordTwoTwoVectorEquivMatrix_apply
TauCeti.realCliffordTwoTwoVectorEquivMatrix_det.
Writing \(\Phi (s)=(P,R)\) for a Spin element, the action is
\[X(svs^{-1})=P X(v)R^{-1}.\]
For the proof, \(e_3^2=-1\), and conjugation
\(\gamma (x)=-e_3xe_3\) fixes \(H_0\) and negates \(I\). Therefore
\[\Phi (\gamma (x))=
\bigl (S\Phi _2(x)S,\ S\Phi _1(x)S\bigr ).\]
The identities
\[e_0e_3=IC,\qquad e_1e_3=-IB,\qquad e_2e_3=-IA\]
give the displayed formula for \(X\). Apply \(\Phi _1\) to
\((svs^{-1})e_3=s(ve_3)\gamma (s^{-1})\), then multiply on the right
by \(S\). Since \(S^2=1\), the result is \(P X(v)R^{-1}\).
This proves TauCeti's exact coordinate action
TauCeti.realSpinTwoTwoEquivSpecialLinearProd_action.
The diagram records the two ways to calculate the same action:
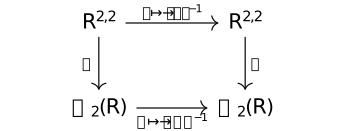
As in the compact action of Example [fcap-003K], multiplication by a fixed vector makes an odd vector accessible to the even algebra, and conjugation by that vector interchanges its two factors. Here the factors are real matrices, with the explicit \(S\)-conjugations above. This is the even-algebra action transport of [porteous1995clifford, Chapter 16, Proposition 16.9, pp. 143--144] in the stated axes. The construction gives the group and its vector action; its orthogonal image retains the spinor-norm qualification of Theorem [fcap-0023].
Definition [ca-000J]Definition [ca-001J]Definition [spin-0012]Definition [spin-000O]
Example. The Lorentzian four-dimensional Spin group is \(SL_2(\mathbb C)\) [fcap-002L]AGENTDRAFTED
Example. The Lorentzian four-dimensional Spin group is \(SL_2(\mathbb C)\) [fcap-002L]AGENTDRAFTED
For \(Q_{1,3}=x_0^2-x_1^2-x_2^2-x_3^2\), put \(A_j=e_0e_j\) for \(1\le j\le 3\) and \(I=e_0e_1e_2e_3\). Then the \(A_j\) square to \(1\) and anticommute, while \[I^2=-1,\qquad A_1A_2A_3=-I.\] For the Pauli matrices \[\sigma _1=\begin {pmatrix}0&1\\1&0\end {pmatrix},\quad \sigma _2=\begin {pmatrix}0&-i\\i&0\end {pmatrix},\quad \sigma _3=\begin {pmatrix}1&0\\0&-1\end {pmatrix},\] the assignments \(\Psi (A_j)=\sigma _j\) define a real-algebra map from the even Clifford algebra to \(M_2(\mathbb C)\). Since \(\sigma _1\sigma _2\sigma _3=i1\), necessarily \(\Psi (I)=-i1\). The images of \(1,A_1,A_2,A_3,I,IA_1,IA_2,IA_3\) form a real basis, so \(\Psi \) is an algebra equivalence.
Write a matrix uniquely as \[M=z_0 1+z_1\sigma _1+z_2\sigma _2+z_3\sigma _3, \qquad z_j=a_j+i b_j,\] where \[\begin {aligned} z_0&=(m_{11}+m_{22})/2,&z_3&=(m_{11}-m_{22})/2,\\ z_1&=(m_{12}+m_{21})/2,&z_2&=(m_{21}-m_{12})/(2i). \end {aligned}\] Then an explicit inverse is \[\Psi ^{-1}(M) =a_0+\sum _{j=1}^3a_jA_j -I\left (b_0+\sum _{j=1}^3b_jA_j\right ).\] Reversal fixes \(I\) and negates every \(A_j\); under \(\Psi \) it is the complex-linear matrix adjugate. Hence \[\Psi (\operatorname {rev}(x))=\operatorname {adj}(\Psi (x)),\qquad \Psi (\operatorname {rev}(x)x)=\det (\Psi (x))1.\] For an arbitrary even \(x\), this norm is algebra-valued: the determinant may be complex, corresponding to the even center. It is not yet the real scalar-valued Lipschitz norm, and adjugation is not conjugate transpose.
Restriction therefore gives a homomorphism \(\operatorname {Spin}(Q_{1,3})\to SL_2(\mathbb C)\). Conversely, a determinant-one matrix has adjugate as a two-sided inverse. Its displayed Clifford preimage is an even unit with \(\operatorname {rev}(x)x=1\), so the dimension-four carrier lemma places it in Spin. The written inverse proves both compositions and multiplicativity: \[\operatorname {Spin}(Q_{1,3})\simeq SL_2(\mathbb C).\]
The source indices require translation. [lawson2016spin, I.3, Theorem 3.7, pp. 23--24] use \(v^2=-q(v)\) and give the even-algebra reduction \[\operatorname {Cl}^{0}_{3,1}\simeq \operatorname {Cl}_{2,1}.\] Their base entries and recurrence then give \[\operatorname {Cl}_{2,1}\simeq M_2(\mathbb C)\] [lawson2016spin, I.4, (4.0) and Theorem 4.1, p. 25].
Gallier uses the opposite indexing. The positive-square \(A_j\) exhibit \(\operatorname {Cl}_{3,0}\). [gallier2014clifford, Example 1.3, p. 33] records the matrix base entries, while [gallier2014clifford, Lemma 1.15, p. 34] supplies the recurrence. Together they give \[\operatorname {Cl}_{3,0} \simeq \operatorname {Cl}_{0,1}\otimes \operatorname {Cl}_{2,0} \simeq M_2(\mathbb C).\]
[porteous1995clifford, Chapter 17, Proposition 17.5, pp. 151--152] identifies his norm-one subgroup \(\operatorname {Spin}^{+}(1,3)\) with \(SL_2(\mathbb C)\). He computes reversal as adjugation. His broader mixed-sign carrier permits norm \(\pm 1\), and his displayed axes are not the Pauli axes fixed above.
Here the even center is \(\mathbb R[I]\simeq \mathbb C\), with no nonzero complementary central idempotents. This contrasts with the split compact center \(\mathbb R\oplus \mathbb R\), although both even algebras have real dimension eight. The full algebra \(\mathcal {C}\kern -2pt\ell _{1,3}\simeq M_2(\mathbb H)\) in Example [fcap-0026] is a different algebra. The vector-action image remains the spinor-norm kernel from Theorem [fcap-0023]; no topological component or concrete gamma-map claim is made.
Lemma. Opposite Lorentz signatures share an even-algebra action dictionary [fcap-003Z]AGENTDRAFTED
Lemma. Opposite Lorentz signatures share an even-algebra action dictionary [fcap-003Z]AGENTDRAFTED
Keep the Pauli convention of Example [fcap-002L]: \(Q_{1,3}(v)=t^2-x_1^2-x_2^2-x_3^2\), \(A_j=e_0e_j\), and \(\Psi (A_j)=\sigma _j\). For \(Q_{3,1}(y)=y_0^2+y_1^2+y_2^2-y_3^2\), write \(f_0,\ldots ,f_3\) for the coordinate generators. The real linear bijection \[T(t,x_1,x_2,x_3)=(-x_2,x_1,-x_3,t)\] satisfies \(Q_{3,1}(Tv)=-Q_{1,3}(v)\). There is a real algebra equivalence \[E:\mathcal {C}\kern -2pt\ell ^+(Q_{1,3})\longrightarrow \mathcal {C}\kern -2pt\ell ^+(Q_{3,1}), \qquad E(vw)=-T(v)T(w).\] It preserves reversion and restricts to an equivalence of the actual Spin groups. Their vector actions satisfy \[T(svs^{-1})=E(s)T(v)E(s)^{-1}.\]
For the construction, complexify and send \(v\mapsto iT(v)\). Its square is \(Q_{1,3}(v)\), so the Clifford universal property gives an algebra map. On an even word of length \(2k\) its value is \((-1)^kT(v_1)\cdots T(v_{2k})\), which is real. This defines \(E\) by scalar extension as in Theorem [fcap-003V]. The reverse construction sends \(w\mapsto iT^{-1}(w)\); the two composites negate generators and therefore fix every even word. Reversing an even word commutes with \(E\). The dimension-four carrier lemma Lemma [fcap-002J] now identifies the reverse-norm-one even units on both sides, so \(E\) and its inverse restrict to the stated actual groups. Applying the complex map to \(svs^{-1}\) and cancelling \(i\) proves the action identity. This is the sign-transfer mechanism used for compact forms in Proposition [fcap-0039], with the additional coordinate change \(T\).
The algebraic construction is also the composite of sign scaling
and the isometry \(T:(-Q_{1,3})\to Q_{3,1}\). TauCeti's general
scaling formula at the unit \(-1\)
TauCeti.CliffordAlgebra.evenEquivEvenSMul_ι,
its reversion compatibility
TauCeti.CliffordAlgebra.evenEquivEvenSMul_reverseEven,
and the isometry formula
CliffordAlgebra.evenEquivOfIsometry_ι
provide these three component statements. The displayed \(T\) and its
Spin-action dictionary are the explicit specialization proved here.
Let \(\Phi :\mathcal {C}\kern -2pt\ell ^+(Q_{3,1})\to M_2(\mathbb C)\) be TauCeti's
concrete matrix equivalence. Its bilinear-generator formula
TauCeti.realCliffordThreeOneEvenEquivComplexMatrix_ι
gives
\[\begin {aligned}
\Phi (f_0f_3)&=-\sigma _2,&\Phi (f_1f_3)&=\sigma _1,&
\Phi (f_2f_3)&=-\sigma _3,\\
\Phi (f_0f_1)&=i\sigma _3,&\Phi (f_0f_2)&=i\sigma _1,&
\Phi (f_1f_2)&=i\sigma _2.
\end {aligned}\]
Since \(T(e_0)=f_3\), \(T(e_1)=f_1\), \(T(e_2)=-f_0\), and
\(T(e_3)=-f_2\), these formulas give \(\Phi (E(A_j))=\sigma _j\).
The \(A_j\) generate the even algebra, hence \(\Phi \circ E=\Psi \).
Also \(E(e_0e_1e_2e_3)=f_0f_1f_2f_3\), whose matrix is \(-i1\).
Thus the Pauli group equivalence agrees, through \(E\), with
TauCeti.realSpinThreeOneEquivSpecialLinear.
This dictionary concerns the even algebras and their Spin actions;
the full real Clifford algebras retain their different signature types.
Example. The Lorentz Spin action is Hermitian matrix congruence [fcap-0040]AGENTDRAFTED
Example. The Lorentz Spin action is Hermitian matrix congruence [fcap-0040]AGENTDRAFTED
In the Pauli model Example [fcap-002L], an odd vector becomes an even element after multiplication by \(e_0\). Encode \(v=te_0+x_1e_1+x_2e_2+x_3e_3\) by \[X(v)=\Psi (ve_0)=t1-\sum _{j=1}^3x_j\sigma _j =\begin {pmatrix}t-x_3&-x_1+i x_2\\-x_1-i x_2&t+x_3\end {pmatrix}.\] A matrix is Hermitian when \(Z^*=Z\), where \(*\) denotes conjugate transpose. Every Hermitian two-by-two matrix has the form \(Z=\begin {pmatrix}a&z\\\overline z&d\end {pmatrix}\) with \(a,d\in \mathbb R\). The inverse coordinates are \[X^{-1}(Z)=\left (\frac {a+d}{2},-\operatorname {Re}z, \operatorname {Im}z,\frac {d-a}{2}\right ).\] Thus \(X\) is a real linear equivalence, and direct expansion gives \[\det X(v)=t^2-x_1^2-x_2^2-x_3^2=Q_{1,3}(v).\]
For \(s\in \operatorname {Spin}(Q_{1,3})\), put \(M=\Psi (s)\in SL_2(\mathbb C)\). Then the vector action is \[X(svs^{-1})=M X(v)M^*.\] To prove it, conjugation by \(e_0\) defines an automorphism \(\gamma (x)=e_0xe_0\) of the even algebra. It negates each \(A_j=e_0e_j\) and the volume element \(I=e_0e_1e_2e_3\). On the matrix side, \(M\mapsto \operatorname {adj}(M)^*\) has the same effect on \(\sigma _j\) and \(-i1\). It is a real algebra automorphism: both adjugation and conjugate transpose reverse products, and in size two adjugation is linear. Checking the even generators therefore gives \[\Psi (\gamma (x))=\operatorname {adj}(\Psi (x))^*.\] Now multiply the Clifford action by \(e_0\): \[(svs^{-1})e_0=s(ve_0)\gamma (s^{-1}).\] Since \(\det M=1\), we have \(\operatorname {adj}(M^{-1})=M\). Applying \(\Psi \) proves the congruence formula. It preserves Hermitian matrices, and its determinant is unchanged because \(\det M=\det M^*=1\).
The square makes the coordinate meaning of the action explicit:
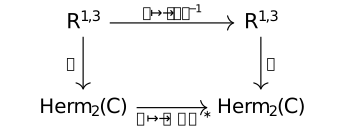
For comparison with the formal opposite-signature model, use
\(T\) and \(E\) from Lemma [fcap-003Z]. TauCeti's vector equivalence has
coordinates
\[H(y)=\begin {pmatrix}y_3+y_2&-y_1-i y_0\\
-y_1+i y_0&y_3-y_2\end {pmatrix},\qquad
\det H(y)=-Q_{3,1}(y)\]
TauCeti.coe_realCliffordThreeOneVectorEquivHermitian_apply
TauCeti.realCliffordThreeOneVectorEquivHermitian_det.
Substitution gives \(H(Tv)=X(v)\). In the even algebra this is the
same identity as \(E(ve_0)=-T(v)f_3\), since
\(H(y)=\Phi (-yf_3)\). The group coercion formula
TauCeti.coe_realSpinThreeOneEquivSpecialLinear_apply
identifies the matrix of \(E(s)\) with \(\Phi (E(s))=\Psi (s)=M\).
Consequently the action dictionary in Lemma [fcap-003Z] translates
TauCeti's exact Hermitian congruence theorem
TauCeti.realSpinThreeOneEquivSpecialLinear_action
into the displayed Pauli action. This checks both the signature sign
and the matrix axes, not just the abstract group type.
Multiplication by a fixed nonisotropic vector is the even-algebra action mechanism of [porteous1995clifford, Chapter 16, Proposition 16.9, pp. 143--144]. His Lorentz group calculation uses adjugation and the norm-one carrier [porteous1995clifford, Chapter 17, Proposition 17.5, pp. 151--152]. The coordinates and conjugate-transpose action above are derived in our chosen axes. The orthogonal image retains the spinor-norm condition of Theorem [fcap-0023]; a topological component identification is separate.
Definition [ca-000J]Definition [spin-000O]
Proposition. The discriminant center of a four-dimensional Spin group [fcap-0043]AGENTDRAFTED
Proposition. The discriminant center of a four-dimensional Spin group [fcap-0043]AGENTDRAFTED
Let \(K\) be a field of characteristic different from two, and let \(q=\langle a,b,c,d\rangle \) with \(a,b,c,d\in K^\times \). Thus \(q(x)=ax_1^2+bx_2^2+cx_3^2+dx_4^2\). The center of its even Clifford algebra determines whether the quaternion description of its Spin group has two factors over \(K\) or one factor over a quadratic field. Put \[\begin {aligned} \delta &=abcd,\\ E&=K[t]/(t^2-\delta ),\\ D&=(-ab,-ac\mid K), \end {aligned}\] using the quaternion algebra notation. The class of \(\delta \) in \(K^\times /(K^\times )^2\) is the signed discriminant in dimension four; changing the diagonalizing basis changes the determinant by a square. Lam's center theorem identifies the corresponding quadratic algebra; the explicit quaternion and group identifications below follow by calculation [lam2005quadratic, V.2, thms. 2.2--2.5, pp. 109--111].
Extend quaternion conjugation \(\overline i=-i\), \(\overline j=-j\) \(E\)-linearly to \(D_E=D\otimes _K E\). Write \(SL_1(D_E)=\{x\in D_E:x\overline x=1\}\) for its norm-one group. Indeed, for \(x=x_0+x_1i+x_2j+x_3ij\), with \(x_r\in E\), \[x\overline x=\overline x x =x_0^2+abx_1^2+acx_2^2+a^2bcx_3^2\in E.\] This extends the reduced norm to the displayed quaternion algebra, and \(x^{-1}=\overline x\) when the norm is one. There are algebra and group isomorphisms \[\begin {aligned} \mathcal {C}\kern -2pt\ell ^+(q)&\simeq D_E,\\ Z(\mathcal {C}\kern -2pt\ell ^+(q))&\simeq E,\\ \operatorname {Spin}(q)&\simeq SL_1(D_E), \end {aligned}\] where the algebra isomorphism takes grade reversion to quaternion conjugation. If \(\delta \) is a square in \(K^\times \), this gives \[\operatorname {Spin}(q)\simeq SL_1(D)\times SL_1(D).\] If \(\delta \) is nonsquare, it gives \[\operatorname {Spin}(q)\simeq SL_1(D\otimes _K K(\sqrt \delta )).\] All groups here consist of points over the indicated fields.
For a concrete comparison, take \(q_d=\langle 1,-1,1,-d\rangle \). Then \(\delta =d\) and \(D=(1,-1\mid K)\). The matrices \[i\longmapsto \begin {pmatrix}1&0\\0&-1\end {pmatrix},\qquad j\longmapsto \begin {pmatrix}0&1\\-1&0\end {pmatrix}\] have squares \(1,-1\), anticommute, and, together with their product and the identity, form a basis of \(M_2(K)\). They therefore identify \(D\) with \(M_2(K)\). Conjugation becomes matrix adjugation and the norm becomes the determinant, giving \(\operatorname {Spin}(q_d)\simeq SL_2(E)\). In particular, over \(K=\mathbb Q\), the members \(q_1\) and \(q_2\) satisfy \[\begin {aligned} \operatorname {Spin}(q_1)(\mathbb Q) &\simeq SL_2(\mathbb Q)\times SL_2(\mathbb Q),\\ \operatorname {Spin}(q_2)(\mathbb Q) &\simeq SL_2(\mathbb Q(\sqrt 2)). \end {aligned}\] These identities apply the proposition to the two centers \(\mathbb Q\times \mathbb Q\) and \(\mathbb Q(\sqrt 2)\).
Proof.
Proof.
Choose orthogonal Clifford generators with \(e_1^2=a,e_2^2=b,e_3^2=c,e_4^2=d\). Distinct generators anticommute. Set \(I=e_1e_2\), \(J=e_1e_3\), and \(w=e_1e_2e_3e_4\). Then \[\begin {aligned} I^2&=-ab,&J^2&=-ac,\\ IJ&=-JI,&w^2&=abcd. \end {aligned}\] The element \(w\) commutes with every even word. Thus \(i\mapsto I\), \(j\mapsto J\), \(t\mapsto w\) define an algebra homomorphism \(D\otimes _K E\longrightarrow \mathcal {C}\kern -2pt\ell ^+(q)\). The eight elements \[1,I,J,IJ,w,Iw,Jw,IJw\] map to nonzero scalar multiples of the eight distinct even Clifford basis monomials. Explicitly, \[\begin {aligned} IJ&=-ae_2e_3,&Iw&=-abe_3e_4,\\ Jw&=ace_2e_4,&IJw&=abce_1e_4. \end {aligned}\] They form a basis, proving bijectivity. Writing an element of \(D_E\) in the basis \(1,i,j,ij\), commutation with \(i\) forces its \(j,ij\) coefficients to vanish, and commutation with \(j\) forces its \(i\) coefficient to vanish. Here \(2,ab,ac\) are units, even when \(E\) is a product. The center is therefore exactly \(E\). Reversion negates \(I,J,IJ\) and fixes \(w\), so it is \(\overline {(\,\cdot \,)}\) on \(D_E\).
It remains to identify the actual vector-generated Spin group with all even elements of reverse norm one. The real four-dimensional argument of Lemma [fcap-002J] works over the stated field as follows. Suppose \(x\in \mathcal {C}\kern -2pt\ell ^+(q)\) and \(\operatorname {rev}(x)x=1\). Finite-dimensionality makes this left inverse a two-sided inverse. For every vector \(v\), \(xvx^{-1}\) is odd and fixed by reversion. In the orthogonal Clifford basis, reversal is \(+1\) on degree one and \(-1\) on degree three. Since two is invertible, \(xvx^{-1}\) is a vector. Its square is \(q(v)\), and conjugation is injective, hence induces an orthogonal automorphism \(g\) of the four-dimensional vector space.
By the Clifford group exact sequence, lift \(g\) to a vector-generated Clifford unit \(y\). For the grading involution \(\alpha \), equality of the twisted actions of \(y\) and the even element \(x\) implies that \(z=y^{-1}x\) satisfies \(\alpha (z)v=vz\) for every vector \(v\). The graded-centrality theorem used in Lemma [fcap-002J] gives \(z=c1\) with \(c\in K^\times \). Every such scalar belongs to the generated Clifford group: for \(q(v)\ne 0\), the two nonisotropic vectors \((c/q(v))v\) and \(v\) have Clifford product \(c1\). Thus \(x=yz\) is in that group. It is even with reverse norm one, so the carrier criterion Remark [fcap-0028] places it in Spin. Conversely, every Spin element is even with reverse norm one by that same criterion. Under the algebra isomorphism this is exactly \(SL_1(D_E)\).
If \(\delta =r^2\) with \(r\in K^\times \), evaluation at \(r,-r\) identifies \(E\) with \(K\times K\). The corresponding central idempotents are \((1+w/r)/2\) and \((1-w/r)/2\). Hence \(D_E\simeq D\times D\), with componentwise conjugation and norm, giving the displayed product of norm-one groups. If \(\delta \) is nonsquare, \(t^2-\delta \) is irreducible, so \(E=K(\sqrt \delta )\) and the second description follows.
The split-center group equivalence has a formal counterpart in
CliffordAlgebra.spinGroupEquivSplitCenterCorners, given a
center isomorphism with \(K\times K\). The field-center existence theorem
CliffordAlgebra.exists_spinGroupEquivQuaternionUnitaryOverCenter_of_finrank_eq_four
gives a quaternion norm-one model over the actual even center. Both assume
nondegeneracy and dimension four over a field with two invertible. The
explicit parameters \(-ab,-ac\) and the matrices for \(q_d\) are supplied
by the calculation above.
Lemma. The volume term does not obstruct Spin in dimension five [fcap-003H]AGENTDRAFTED
Lemma. The volume term does not obstruct Spin in dimension five [fcap-003H]AGENTDRAFTED
Let \(K\) be a field of characteristic different from two, and let
\((V,Q)\) be a nondegenerate quadratic space of dimension five over \(K\).
For \(x\in \mathcal {C}\kern -2pt\ell ^{+}(Q)\),
\[x\text { is the Clifford value of a Spin element}
\quad \Longleftrightarrow \quad \operatorname {rev}(x)x=1.\]
The norm condition implies Lipschitz membership in this dimension
CliffordAlgebra.evenUnitaryGroup_le_lipschitzGroup_of_finrank_eq_five.
The point is to remove the possible degree-five term left by the
dimension-four argument of Lemma [fcap-002J].
Choose an orthogonal basis \(e_1,\ldots ,e_5\), suppress the generator map, and put \(\omega =e_1\cdots e_5\). Nondegeneracy gives \[\omega ^2=\delta 1,\qquad \delta =\prod _{i=1}^5 Q(e_i)\ne 0.\] The element \(\omega \) is central and invertible. Suppose \(\operatorname {rev}(x)x=1\). Finite dimensionality makes the left inverse a two-sided inverse. For any \(v\in V\), the element \(y=xvx^{-1}\) is odd and satisfies \(\operatorname {rev}(y)=y\). In the orthogonal monomial basis, reversal has signs \(+1,-1,+1\) on degrees one, three and five. Hence \[y=w+c\omega \qquad (w\in V,\ c\in K).\]
Conjugation preserves the scalar square of a vector. Since \(\omega \) is central, \[Q(v)1=y^2=Q(w)1+2c\omega w+c^2\delta 1.\] Each \(\omega e_i\) is a nonzero scalar multiple of the product of the other four basis vectors. Thus \(\omega w\) has pure degree four in this basis, whereas the other terms in the equation are scalar. Independence of the Clifford basis gives \(2c\omega w=0\). As two and \(\omega \) are invertible, either \(c=0\) or \(w=0\). In the latter case \(y=c\omega \) is central, so conjugating back gives \(v=x^{-1}yx=y=c\omega \). The degree-one and degree-five subspaces have zero intersection; therefore \(v=0\) and \(c=0\). In both cases \(y\in V\).
Thus \(x\) normalizes the vector space. The Clifford-group
characterization makes it Lipschitz; together with evenness and reverse
norm one, this is the Spin criterion of Remark [fcap-0028]. The reverse
implication is that same criterion. In fact the carrier equality holds in
every dimension from one through five
CliffordAlgebra.range_spinGroup_toUnits_eq_evenUnitaryGroup.
The lower bound matters: in dimension zero the vector-generated Lipschitz
group is trivial, whereas the even-unitary group contains both \(1\) and
\(-1\). This carrier equality alone supplies no symplectic matrix model;
the spinor pairing and matrix inverse for complex dimension five remain
the separate argument of Proposition [fcap-0033].
Porteous gives the real dimension-five proof by separating the vector, trivector and volume terms [porteous1995clifford, Chapter 16, Proposition 16.15, p. 147]. His relation is \(v^2=-q(v)\), so here \(Q=-q\); his conjugation is \(\operatorname {rev}\circ \alpha \), equal to reversal on even elements. His indefinite Spin carrier permits norm \(\pm 1\); we select norm \(+1\). The basis calculation above extends the norm-one argument from real spaces to the stated fields: orthogonality, nonzero basis squares and invertibility of two replace any need for real unit-length normalization. Gallier records the compact boundary at five and the failure at six [gallier2014clifford, Section 1.4, closing Remark, p. 31]; the next example computes that failure.
Example. A norm-one even unit can leave the vector space in dimension six [fcap-003I]AGENTDRAFTED
Example. A norm-one even unit can leave the vector space in dimension six [fcap-003I]AGENTDRAFTED
Let \(K\) be a field of characteristic different from two, and let \((V,Q)\) be a finite-dimensional nondegenerate quadratic space containing six orthogonal vectors \(e_1,\ldots ,e_6\) with \(Q(e_i)\ne 0\). Put \[\omega =e_1\cdots e_6,\qquad \delta =\prod _{i=1}^6 Q(e_i).\] Now \(\omega \) is even, \(\operatorname {rev}(\omega )=-\omega \), and \(\omega ^2=-\delta 1\). It anticommutes with each of the six displayed vectors. If \(a,b\in K\) satisfy \(a^2+\delta b^2=1\), then \[x=a+b\omega ,\qquad x^{-1}=\operatorname {rev}(x)=a-b\omega \] is an even unit of reverse norm one. Its action on a displayed basis vector is \[xe_i x^{-1}=(a^2-\delta b^2)e_i+2ab\omega e_i.\]
For \(ab\ne 0\), the last term is a nonzero degree-five monomial,
up to a scalar. Extend the six vectors to an orthogonal basis; independence
of the Clifford monomials shows that the displayed conjugate is not a
vector. Since \(x\) is even, ordinary and twisted conjugation agree.
Thus \(x\) is not Lipschitz and cannot belong to Spin, despite satisfying
the norm equation
CliffordAlgebra.notMem_lipschitzGroup_of_mem_evenUnitaryGroup_of_coe_eq.
Only the selected six vectors are used: in higher dimension \(\omega \)
commutes with an additional orthogonal vector, which does not affect this
counterexample.
For a concrete compact example, take \(K=\mathbb R\) and \(Q(v)=v_1^2+\cdots +v_6^2\). With \(a=b=1/\sqrt 2\), one obtains \[x=\frac {1+\omega }{\sqrt 2},\qquad \operatorname {rev}(x)x=1,\qquad xe_1x^{-1}=\omega e_1=-e_2e_3e_4e_5e_6.\] Porteous [porteous1995clifford, Chapter 16, p. 146] exhibits the unnormalized element \(1+\omega \) of norm two.
Gallier [gallier2014clifford, Section 1.4, closing Remark, p. 31] uses the normalized element above.
Their compact generators square to \(-1\). With that choice the same six-vector product still squares to \(-1\), but \(\omega e_1=+e_2e_3e_4e_5e_6\). Both signs give the same obstruction. The calculation here uses the positive-square convention of Example [fcap-002H].
Over any infinite \(K\) as above, the conic always supplies
\(a,b\ne 0\). Indeed, choose \(t\ne 0\) with \(1+\delta t^2\ne 0\) and
\(1-\delta t^2\ne 0\), and set
\[a=\frac {1-\delta t^2}{1+\delta t^2},\qquad
b=\frac {2t}{1+\delta t^2}.\]
Only finitely many values of \(t\) are excluded, and substitution gives
\(a^2+\delta b^2=1\). Consequently the Spin image is a proper subgroup
of the even-unitary group for every nondegenerate form of dimension at
least six over an infinite field of characteristic different from two
CliffordAlgebra.range_spinGroup_toUnits_ne_evenUnitaryGroup_of_six_le_finrank.
This field extension follows from the displayed calculation; the cited
book passages concern real spaces. Over a finite field the conditional
six-vector construction remains valid, but this infinitude argument makes
no assertion that a suitable conic point exists.
Remark. From real recurrences to the residue table [fcap-0016]AGENTDRAFTED
Remark. From real recurrences to the residue table [fcap-0016]AGENTDRAFTED
The mixed \((1,1)\) recurrence removes matched axes but leaves a one-sided algebra \(\mathcal {C}\kern -2pt\ell _{r,0}\) or \(\mathcal {C}\kern -2pt\ell _{0,r}\), which it cannot classify. Together with the signature switch in Theorem [fcap-001X] and initial entries in Example [fcap-0015], the two recurrences below complete the calculation.
The two one-sided recurrences are
\[\begin {aligned}
\mathcal {C}\kern -2pt\ell _{p,q+2}&\simeq \mathcal {C}\kern -2pt\ell _{q,p}\otimes _{\mathbb R}\mathbb H,\\
\mathcal {C}\kern -2pt\ell _{p+8,q}&\simeq \mathcal {C}\kern -2pt\ell _{p,q}\otimes _{\mathbb R}M_{16}(\mathbb R).
\end {aligned}\]
The first line is the actual equivalence
TauCeti.realCliffordQuaternionRecurrenceEquiv. For the
second, the formal theorem supplies existence
TauCeti.nonempty_realCliffordEightPeriodicityEquiv.
They yield the residue-indexed mod-eight classification
TauCeti.realClifford_classification. The classical table is
[lawson2016spin, I.4, Theorem 4.3 and Tables I--II, pp. 27--29].
Example. The real Clifford algebra of signature (1,3) [fcap-0026]
L∃∀NAGENTDRAFTED
Example. The real Clifford algebra of signature (1,3) [fcap-0026]
L∃∀NAGENTDRAFTED
Use the convention of Convention [fcap-0011]: \(p\) counts positive squares, \(q\) counts negative squares, and a Clifford generator obeys \(v^2=Q(v)1\). Then the real algebra for one positive and three negative axes is \[\mathcal {C}\kern -2pt\ell _{1,3}\simeq M_2(\mathbb H).\] The Tau Ceti classification theorem states existence of an abstract real algebra equivalence. Here \(q-p=2\) is its residue modulo \(8\), and its matrix size is \(2^{(p+q-2)/2}=2\).
[chevalley1954algebraic, II.2.9, pp. 65--66] uses the same positive/negative index convention. Split off one hyperbolic plane of signature \((1,1)\); the orthogonal remainder is a negative plane of signature \((0,2)\). Chevalley's dimension-two definite calculation on p. 66 identifies its Clifford algebra with \(\mathbb H\). The hyperbolic-plane theorem [chevalley1954algebraic, II.2.1, pp. 42--43] gives \(\mathcal {C}\kern -2pt\ell _{1,1}\simeq M_2(\mathbb R)\).
[chevalley1954algebraic, II.2.5, pp. 45--46] gives an orthogonal-sum tensor-product formula for an even-dimensional nondegenerate first summand; the second quadratic form is twisted. Here normalized hyperbolic generators \(e^2=1\) and \(f^2=-1\) have volume \(J=ef\) with \(J^2=1\). For a vector \(v\) in the orthogonal remainder, \(Jv\) commutes with \(e,f\) and still squares to \(Q(v)\). Since \(v=J(Jv)\), these commuting factors generate the full algebra. Thus the special hyperbolic split leaves that remainder unchanged: \[\begin {aligned} \mathcal {C}\kern -2pt\ell _{1,3}&\simeq \mathcal {C}\kern -2pt\ell _{1,1}\otimes _{\mathbb R}\mathcal {C}\kern -2pt\ell _{0,2}\\ &\simeq M_2(\mathbb R)\otimes _{\mathbb R}\mathbb H \simeq M_2(\mathbb H). \end {aligned}\] Both sides have real dimension \(16=2^4=4\dim _{\mathbb R}\mathbb H\). By comparison, \(M_4(\mathbb C)\) has real dimension \(32\). This abstract classification alone does not identify any particular gamma-matrix map, its kernel, or its image; the concrete Dirac map is treated in Proposition [fcap-002U].
Proposition. The real algebra generated by the Dirac gamma matrices [fcap-002U]AGENTDRAFTED
Proposition. The real algebra generated by the Dirac gamma matrices [fcap-002U]AGENTDRAFTED
On \(\mathbb R^4\), let
\[q_\gamma (v)=v_0^2-v_1^2-v_2^2-v_3^2.\]
Under the coordinate identification
\(\operatorname {Fin}(4)=\operatorname {Fin}(1+3)\), the identity map is an
isometry from \(q_\gamma \) to the signature form \(Q_{1,3}\) of
Example [fcap-0026]. This is equality of the displayed forms, rather than only
equality of their signatures. Thus the Clifford transport of
Proposition [fcap-0029] and the classification in Example [fcap-0026] give
\[\mathcal {C}\kern -2pt\ell (q_\gamma )\simeq \mathcal {C}\kern -2pt\ell _{1,3}\simeq M_2(\mathbb H)\]
as real algebras. The selected formal ingredients are the coordinate formula
TauCeti.realCliffordForm_apply and the residue-two
classification
TauCeti.realClifford_classification_of_residue_eq_two;
the latter supplies existence of an abstract equivalence, not a theorem
about a particular gamma-matrix map.
Let \(\xi :\operatorname {Fin}(1)\sqcup \operatorname {Fin}(3) \simeq \operatorname {Fin}(4)\) be the standard index equivalence, and write \[\Gamma _i=\operatorname {endEquivMatrix} \bigl (\operatorname {gamma}(\xi ^{-1}i)\bigr ).\] These are the concrete matrices \(\gamma ^0,\gamma ^1,\gamma ^2,\gamma ^3\); their squares are \(+1,-1,-1,-1\), and distinct matrices anticommute. Put \[D_\gamma =\operatorname {Alg}_{\mathbb R} \langle \Gamma _0,\Gamma _1,\Gamma _2,\Gamma _3\rangle \subset M_4(\mathbb C).\] Physlib constructs the real unital algebra homomorphism \[\rho :\mathcal {C}\kern -2pt\ell (q_\gamma )\longrightarrow D_\gamma ,\qquad \rho \bigl (\iota _{q_\gamma }(v)\bigr )=\sum _{i=0}^3v_i\Gamma _i\] from the Clifford universal property and proves that it is surjective onto \(D_\gamma \); see the generator-map source and the surjectivity source. The codomain here is the generated real subalgebra, not all of \(M_4(\mathbb C)\).
It remains to prove that this actual map has zero kernel. First, \(M_2(\mathbb H)\) is simple. Let \(J\) be a nonzero two-sided ideal, choose a matrix \(A\in J\) with nonzero entry \(a=A_{ij}\), and let \(E_{kl}(b)\) denote the matrix whose only nonzero entry is \(b\) in position \((k,l)\). Since every nonzero quaternion is invertible, for all \(k,l\) one has \[E_{ki}(a^{-1})\,A\,E_{jl}(1)=E_{kl}(1)\in J.\] The order of the factors matters over \(\mathbb H\). Taking both diagonal matrix units and adding them gives \(1\in J\), so \(J=M_2(\mathbb H)\). Transport through the preceding equivalence makes \(\mathcal {C}\kern -2pt\ell (q_\gamma )\) simple. Hence \(\ker \rho \) is zero or the entire source. The second option is impossible because \(\rho \) is unital and the identity matrix in \(D_\gamma \subset M_4(\mathbb C)\) is nonzero. Therefore \(\rho \) is injective; together with the formal surjectivity, this proves that this same map is a real algebra equivalence \[\mathcal {C}\kern -2pt\ell (q_\gamma )\simeq _{\rho }D_\gamma .\]
Consequently \[\dim _{\mathbb R}D_\gamma =\dim _{\mathbb R}M_2(\mathbb H)=4\cdot 4=16.\] For the ambient algebra, \[\dim _{\mathbb R}M_4(\mathbb C)=16\cdot 2=32.\] Thus \(D_\gamma \) is a proper real subalgebra of the ambient complex matrix algebra. This conclusion uses the proved equivalence and does not assume the image dimension in order to deduce injectivity.
Lawson--Michelsohn invoke simplicity of \(M_n(K)\) for \(K=\mathbb R,\mathbb C,\mathbb H\) in their real representation theorem [lawson2016spin, I.5, Theorem 5.6, pp. 31--32]. The matrix-unit calculation above supplies that step for the quaternionic algebra and then applies it to Physlib's concrete homomorphism. Their convention is \(v^2=-q(v)1\), so our \(\mathcal {C}\kern -2pt\ell _{1,3}\) is their \(\mathcal {C}\kern -2pt\ell _{3,1}\). Their algebra in that convention is the quaternionic matrix algebra used in the simplicity argument. The abstract classification is formalized in Tau Ceti, and Physlib formalizes the concrete map and its surjectivity. The simplicity and kernel argument completing the equivalence here is informal; no whole-card formal badge is asserted.
Notes on foundational group algebras (for) physics [fgap-0001]
📄PDFAGENTDRAFTED
- July 28, 2026
- Utensil Song
Notes on foundational group algebras (for) physics [fgap-0001]
📄PDFAGENTDRAFTED
- July 28, 2026
- Utensil Song
These are the accompanying mathematical notes for the experimental research project FGAP. FGAP is read “F-gap,” for the foundational gap between established mathematical tools and open questions about physical structures, especially beyond the Standard Model. It is also a coined acronym for “Foundational Group Algebras (for) Physics.”
The project studies mathematical structures that may help us understand physical structures more deeply. It does not construct or claim a physical theory. The current storyline has been strongly shaped by agent exploration of one spike-test slice of that research domain. It follows the project's approach: turn a structural hypothesis into a small, source-grounded vertical slice, then use explicit calculations and formalization to expose its assumptions.
This slice begins with Hamilton's Quaternions and the quaternionic realization of the binary tetrahedral group, because they give a small and explicit route into finite real Group Algebras. For the human-curated storyline of the notes, see § [spin-0010].
For the mathematics, we follow the Hurwitz-unit treatment in [voight2021quaternion, ch. 11]. We keep the mathematics and the physical suggestions separate.
Remark. why begin with 2T? [fgap-0018]AGENTDRAFTED
Remark. why begin with 2T? [fgap-0018]AGENTDRAFTED
The binary tetrahedral group \(2T\) is small enough for explicit calculations, yet it connects finite symmetry, representations, real Group Algebras, and the quaternionic structures familiar from spin mathematics. Its concrete realization by Hurwitz units, and their identification with \(2T\), are described in [voight2021quaternion, sec. 11.2, pp. 166--168], while the relation between representations and Group-Algebra modules is developed in [sengupta2010representations, secs. 3.1--3.3, pp. 39--42]. Wilson uses order-3 automorphisms of \(Q_8\) to discuss possible physical interpretations in [wilson2021finite, sec. 4.3, pp. 12--13, v5]. He later adjoins an abstract generator \(f\) of order 3 to \(Q_8\) to form \(2T\) in [wilson2021finite, sec. 6.1, p. 18, v5].
Any physical identification remains a hypothesis. A proposed correspondence must specify an action and representation, an algebra map, any preserved structure or form, a unit-group choice where applicable, and the intended physical meaning. Resemblance alone is not a model.
Quaternion and Hurwitz foundations [fgap-0019]AGENTDRAFTED
Quaternion and Hurwitz foundations [fgap-0019]AGENTDRAFTED
We first introduce Hamilton's Quaternions, the Hurwitz order, and a distinguished unit. Its order and conjugation action provide the concrete calculations used by the group constructions in the next two sections.
Definition. Hamilton's Quaternions [fgap-0006]AGENTDRAFTED
- July 28, 2026
Definition. Hamilton's Quaternions [fgap-0006]AGENTDRAFTED
- July 28, 2026
The algebra of real quaternions is the 4-dimensional real vector space \[ \mathbb {H} =\mathbb {R}1\oplus \mathbb {R}i\oplus \mathbb {R}j\oplus \mathbb {R}k. \] Thus every quaternion can be written uniquely as \[ q=a+bi+cj+dk,\qquad a,b,c,d\in \mathbb {R}. \] Addition and real scalar multiplication are coordinatewise. Multiplication is extended bilinearly from \(1\) as the multiplicative identity and the table \[ \begin {gathered} i^2=j^2=k^2=ijk=-1,\\ ij=k,\quad jk=i,\quad ki=j,\\ ji=-k,\quad kj=-i,\quad ik=-j. \end {gathered} \] This makes \(\mathbb {H}\) an associative, noncommutative real algebra. In Voight's notation, \(\mathbb {H}=(-1,-1\mid \mathbb {R})\); see [voight2021quaternion, def. 2.2.1 and ex. 2.2.3].
More generally, when \(F\) is a field of characteristic different from \(2\) and \(a,b\in F^\times \), the symbol \[ (a,b\mid F) \] denotes the quaternion algebra over \(F\) generated by elements \(i,j\) with \[ i^2=a,\qquad j^2=b,\qquad ji=-ij. \] The two slots record the scalars assigned to the squares of the two generators. With \(k=ij\), the elements \(1,i,j,k\) form an \(F\)-basis. Thus the two entries \(-1,-1\) in \((-1,-1\mid \mathbb {R})\) say precisely that \(i^2=-1\) and \(j^2=-1\); the anticommutation relation then gives \(k^2=-1\).
For \(q=a+bi+cj+dk\), its quaternion conjugate and reduced norm are \[ \overline {q}=a-bi-cj-dk,\qquad \operatorname {nrd}(q)=q\overline {q} =a^2+b^2+c^2+d^2. \] We also have \(\overline {q}q=\operatorname {nrd}(q)\). If \(q\ne 0\), then \(\operatorname {nrd}(q)>0\) and \[ q^{-1}=\frac {\overline {q}}{\operatorname {nrd}(q)}. \] So every nonzero quaternion is invertible. This is the standard involution and reduced norm specialized to Hamilton's Quaternions; see [voight2021quaternion, secs. 3.1--3.3].
The corresponding Mathlib type is Quaternion.
Definition. the Hurwitz order and its units [fgap-0016]AGENTDRAFTED
- July 29, 2026
Definition. the Hurwitz order and its units [fgap-0016]AGENTDRAFTED
- July 29, 2026
Inside the rational quaternion algebra \(B=(-1,-1\mid \mathbb {Q})\), let \(k=ij\) and \[ \omega =\frac {-1+i+j+k}{2}. \] The Lipschitz order and Hurwitz order are the \(\mathbb {Z}\)-lattices \[ \begin {aligned} L&=\mathbb {Z}+\mathbb {Z}i+\mathbb {Z}j+\mathbb {Z}k,\\ \mathcal {O} &=\mathbb {Z}+\mathbb {Z}i+\mathbb {Z}j+\mathbb {Z}\omega . \end {aligned} \] Both are subrings containing \(1\). The order \(\mathcal {O}\) contains \(L\) with index \(2\); it is the unique order properly containing \(L\), and it is maximal. See [voight2021quaternion, sec. 11.1, esp. lem. 11.1.2].
A Hurwitz unit is a unit of \(\mathcal {O}\). Equivalently, it is an element \(q\in \mathcal {O}\) whose reduced norm is \(1\). Voight calculates that \(\mathcal {O}^{\times }\) has \(24\) elements in [voight2021quaternion, sec. 11.2, pp. 166--168]. The particular unit \(\omega \) will give the cyclic factor used below.
Remark. why the Hurwitz order is introduced [fgap-0017]AGENTDRAFTED
- July 29, 2026
Remark. why the Hurwitz order is introduced [fgap-0017]AGENTDRAFTED
- July 29, 2026
Hurwitz developed integral quaternions in 1919. Starting from the Lipschitz order \(L\), the question is not merely which quaternions have integral coordinates, but which order has the better arithmetic structure. The Lipschitz order is not maximal. Voight compares this with enlarging \(\mathbb {Z}[\sqrt {-3}]\) to the Eisenstein integers. Since \(a=i+j+k\) satisfies \(a^2=-3\), the analogous element \[ \omega =\frac {-1+a}{2} \] satisfies \(\omega ^2+\omega +1=0\). Adjoining it enlarges \(L\) to the maximal Hurwitz order \(\mathcal {O}\). See [voight2021quaternion, sec. 11.1, pp. 165--166].
This enlargement supplies more than a convenient lattice. Its \(24\) units form the binary tetrahedral group, and conjugation by \(\omega \) cyclically permutes the quaternion units \(i,j,k\). The same order also supports a norm-Euclidean algorithm. These features make the Hurwitz order a small meeting point of quaternion arithmetic, finite-group structure, and explicit calculation; see [voight2021quaternion, secs. 11.2--11.3, pp. 166--169].
Lemma. a Hurwitz unit of order \(3\) [fgap-0003]AGENTDRAFTED
Lemma. a Hurwitz unit of order \(3\) [fgap-0003]AGENTDRAFTED
Let \[ a=i+j+k,\qquad \omega =\frac {-1+i+j+k}{2}=\frac {-1+a}{2}. \] Then \(\omega \) is a Hurwitz unit of order \(3\). This choice appears in [voight2021quaternion, p. 165].
The mixed terms in \(a^2\) cancel in pairs: \[ \begin {aligned} a^2 &=i^2+j^2+k^2+(ij+ji)+(jk+kj)+(ki+ik)\\ &=-3. \end {aligned} \] It follows that \[ \begin {aligned} \omega ^2 &=\frac {(-1+a)^2}{4}\\ &=\frac {1-2a+a^2}{4}\\ &=\frac {-1-a}{2}. \end {aligned} \] Hence \(\omega ^2+\omega +1=0\), and multiplication by \(\omega -1\) gives \[ \omega ^3=1. \] Thus \(\omega \) is invertible, has inverse \(\omega ^{-1}=\omega ^2=(-1-i-j-k)/2\), and has order \(3\) because \(\omega \ne 1\).
Convention. left conjugation [fgap-0002]AGENTDRAFTED
Convention. left conjugation [fgap-0002]AGENTDRAFTED
For a nonzero quaternion \(q\), we use left conjugation to mean \[ q\mathbin {\triangleright }x=qxq^{-1}. \] See the remark on the conjugation calculation for why the direction is recorded explicitly.
Quaternions can also be obtained from suitable Clifford Algebras; see Notes on Clifford Algebras. Here we use the multiplication in Hamilton's Quaternions directly.
Example. conjugation by a Hurwitz unit [fgap-0004]AGENTDRAFTED
Example. conjugation by a Hurwitz unit [fgap-0004]AGENTDRAFTED
Consider left conjugation by the Hurwitz unit \(\omega =(-1+i+j+k)/2\). We have \[ \omega i\omega ^{-1}=k,\qquad \omega j\omega ^{-1}=i,\qquad \omega k\omega ^{-1}=j. \] Thus the cycle is \(i\mapsto k\mapsto j\mapsto i\). Voight says that conjugation cyclically rotates these units in [voight2021quaternion, sec. 11.2.4, p. 168]; the calculation here fixes the direction. Wilson discusses an abstract order-3 automorphism cycling the quaternion generators in [wilson2021finite, sec. 4.3, pp. 12--13, v5]. That discussion does not select the exact quaternion or fix the oriented cycle calculated here.
It is enough to calculate \[ \omega i=k\omega ,\qquad \omega j=i\omega ,\qquad \omega k=j\omega . \] For example, \[ \omega i =\frac {-1-i+j-k}{2} =k\omega . \] Right multiplication by \(\omega ^{-1}\) proves the three conjugation equations.
Remark. what the conjugation calculation gives [fgap-0005]AGENTDRAFTED
- July 28, 2026
Remark. what the conjugation calculation gives [fgap-0005]AGENTDRAFTED
- July 28, 2026
Saying that conjugation cyclically permutes \(i,j,k\) does not by itself tell us which cycle is meant. Left conjugation by \(\omega \) gives the cycle in the conjugation example. Conjugation by \(\omega ^{-1}\) gives the inverse cycle. This is why we record the three equations instead of only saying "cyclically permutes."
The calculation supplies the first concrete group action used for the binary tetrahedral group. The next notes restrict this action to the quaternion subgroup and then use it in the semidirect-product construction. The three equations alone do not identify the complete set of \(24\) Hurwitz units with that group.
In Lean, the three equations give the computational interface to
Mathlib's Quaternion type.
The abstract action is then recovered from this concrete calculation.
Quaternion and order-three subgroups [fgap-0007]AGENTDRAFTED
- July 28, 2026
Quaternion and order-three subgroups [fgap-0007]AGENTDRAFTED
- July 28, 2026
We now separate two small groups inside the nonzero quaternions. The first is the quaternion group generated by \(i\) and \(j\). The second is generated by the Hurwitz unit \(\omega \). Conjugation by \(\omega \) then tells us how the second group acts on the first.
This is the concrete input for a later construction of the binary tetrahedral group. We stop before that construction here: the present notes only define the two factors and calculate their action.
Definition. group action [fgap-0008]AGENTDRAFTED
Definition. group action [fgap-0008]AGENTDRAFTED
A left action of a group \(G\) on a set \(X\) is a map \[ G\times X\longrightarrow X,\qquad (g,x)\longmapsto g\mathbin {\cdot }x \] such that \[ 1\mathbin {\cdot }x=x,\qquad g_1\mathbin {\cdot }(g_2\mathbin {\cdot }x) =(g_1g_2)\mathbin {\cdot }x. \] Equivalently, an action is a group homomorphism \[ \alpha :G\longrightarrow \operatorname {Sym}(X), \] where \(\operatorname {Sym}(X)\) is the group of permutations of \(X\). We use left actions throughout these notes. See [woit2024quantum, sec. 1.3.2, pp. 7--9].
If \(X=H\) is a group and each permutation preserves multiplication, the action is a homomorphism \[ \alpha :G\longrightarrow \operatorname {Aut}(H). \] Its kernel is \(\ker \alpha \). The action is faithful when \(\alpha \) is injective.
Suppose \(G\) acts on both \(X\) and \(Y\). A map \(f:X\to Y\) is equivariant if \[ f(g\mathbin {\cdot }x)=g\mathbin {\cdot }f(x) \] for every \(g\in G\) and \(x\in X\). Equivariance is how an action passes between two different models of the same object.
Definition. the quaternion group inside Hamilton's Quaternions [fgap-0009]AGENTDRAFTED
- July 28, 2026
Definition. the quaternion group inside Hamilton's Quaternions [fgap-0009]AGENTDRAFTED
- July 28, 2026
Inside the group \(\mathbb {H}^{\times }\) of nonzero quaternions, let \[ Q=\{\pm 1,\pm i,\pm j,\pm k\}. \] The multiplication table for Hamilton's Quaternions shows that this set is closed under multiplication and inverses. It is therefore a subgroup of \(\mathbb {H}^{\times }\).
The elements \(i\) and \(j\) satisfy \[ i^4=1,\qquad i^2=j^2=-1,\qquad ji=i^{-1}j. \] These are the usual relations for the quaternion group. Hence \(Q\) is a concrete copy of \(Q_8\). Voight identifies the same 8 units in [voight2021quaternion, sec. 11.2, p. 166].
Here \(Q\) always means this particular subgroup of the quaternions. An abstract quaternion group will be introduced only when a distinction between models is useful.
Lemma. normal forms in the quaternion subgroup [fgap-000A]AGENTDRAFTED
Lemma. normal forms in the quaternion subgroup [fgap-000A]AGENTDRAFTED
Every element of \(Q\) has a unique normal form \[ i^a j^b,\qquad 0\leq a<4,\quad 0\leq b<2. \] Consequently, \[ Q=\langle i,j\rangle =\{i^a j^b:0\leq a<4,\ 0\leq b<2\} \] and \(Q\) has 8 elements.
Proof.
Proof.
The relation \(ji=i^{-1}j\) moves each occurrence of \(j\) to the right. The relations \(i^4=1\) and \(j^2=i^2\) then reduce every word in \(i,j\) to the stated form. The 8 resulting quaternions are
\[ \begin {array}{cccc} 1&i&-1&-i\\ j&k&-j&-k. \end {array} \]Their coordinates in \(\mathbb {H}=\mathbb {R}1\oplus \mathbb {R}i\oplus \mathbb {R}j\oplus \mathbb {R}k\) are distinct, so the normal forms are unique.
The two-row display will also be useful when the concrete subgroup is compared with an abstract presentation of \(Q_8\). See [voight2021quaternion, sec. 11.2, p. 166].
Lemma. the cyclic subgroup generated by the Hurwitz unit [fgap-000B]AGENTDRAFTED
Lemma. the cyclic subgroup generated by the Hurwitz unit [fgap-000B]AGENTDRAFTED
Let \[ \omega =\frac {-1+i+j+k}{2}. \] The calculation in a Hurwitz unit of order \(3\) gives \(\omega ^3=1\) and \(\omega \neq 1\). It follows that \[ C=\langle \omega \rangle =\{1,\omega ,\omega ^2\} \] is a cyclic subgroup of \(\mathbb {H}^{\times }\) of order 3. In particular, \(C\cong \mathbb {Z}/3\mathbb {Z}\). This subgroup appears in [voight2021quaternion, sec. 11.2.4, p. 168].
Proof.
Proof.
Every power of \(\omega \) reduces modulo 3, so \(C\subseteq \{1,\omega ,\omega ^2\}\). The reverse inclusion is immediate. If \(\omega ^2=1\), multiplying by \(\omega \) would give \(\omega =1\), contrary to the coordinate formula. Thus the 3 displayed elements are distinct.
Example. the Hurwitz action on the quaternion group [fgap-000C]AGENTDRAFTED
Example. the Hurwitz action on the quaternion group [fgap-000C]AGENTDRAFTED
The subgroup \(C\) acts on \(Q\) by left conjugation: \[ C\longrightarrow \operatorname {Aut}(Q),\qquad c\longmapsto (q\longmapsto cqc^{-1}). \] Indeed, conjugation by a Hurwitz unit gives \[ \omega i\omega ^{-1}=k,\qquad \omega k\omega ^{-1}=j,\qquad \omega j\omega ^{-1}=i. \] Thus conjugation by the generator preserves all 8 elements of \(Q\). Its conjugation powers preserve \(Q\) as well, so every \(c\in C\) gives the stated automorphism. The generator's action can be read from the two oriented cycles \[ i\longmapsto k\longmapsto j\longmapsto i, \qquad -i\longmapsto -k\longmapsto -j\longmapsto -i, \] while \(1\) and \(-1\) are fixed.
Conjugation preserves products: \[ c(q_1q_2)c^{-1}=(cq_1c^{-1})(cq_2c^{-1}). \] It is therefore an automorphism of \(Q\); its inverse is conjugation by \(c^{-1}\). The action law follows from \[ (c_1c_2)q(c_1c_2)^{-1} =c_1(c_2qc_2^{-1})c_1^{-1}. \] This verifies the action directly rather than inferring it from the picture. Voight records the normality of \(Q\) and the cyclic rotation in [voight2021quaternion, sec. 11.2.4, p. 168].
Remark. concrete and abstract factor models [fgap-000D]AGENTDRAFTED
Remark. concrete and abstract factor models [fgap-000D]AGENTDRAFTED
The subgroups \(Q,C\leq \mathbb {H}^{\times }\) are concrete: their elements are quaternions, and the Hurwitz action is quaternion conjugation. The abstract groups \[ Q_8,\qquad \mathbb {Z}/3\mathbb {Z} \] remember the same group structures without remembering their quaternion coordinates.
Matching names and cardinalities does not identify these models. We need explicit isomorphisms \[ Q_8\mathbin {\cong }Q,\qquad \mathbb {Z}/3\mathbb {Z}\mathbin {\cong }C. \] The action must then be transported through these isomorphisms and proved equivariant. This keeps later abstract calculations connected to the quaternion realization that supplied them.
In Lean, QuaternionGroup at parameter \(2\) models the abstract
quaternion factor, and Multiplicative applied to ZMod at
modulus \(3\) models the abstract cyclic factor. The
concrete subgroups remain the main computational model. Explicit isomorphisms
recover the abstract interface from that model, and equivariance connects the
transported action to quaternion conjugation. Formalization therefore keeps
these bridges as results rather than treating them as definitions.
From the Hurwitz action to the binary tetrahedral group [fgap-000E]AGENTDRAFTED
- July 28, 2026
From the Hurwitz action to the binary tetrahedral group [fgap-000E]AGENTDRAFTED
- July 28, 2026
The action calculated in the Hurwitz action on the quaternion group now lets us combine the quaternion group \(Q\) and the cyclic group \(C\). We first recall the general steps: normalization makes a set product into a subgroup, complementarity gives unique factorization, and unique factorization produces an internal semidirect product.
Applying these steps inside \(\mathbb {H}^{\times }\) gives a concrete group with 24 elements: \[ Q,\ C \longrightarrow T=Q\vee C=QC \longrightarrow T\cong Q\rtimes C. \] The last isomorphism compares two models; it does not identify their elements.
Definition. normalizer of a subgroup [fgap-000F]AGENTDRAFTED
- July 28, 2026
Definition. normalizer of a subgroup [fgap-000F]AGENTDRAFTED
- July 28, 2026
Let \(N\) be a subgroup of \(G\). The normalizer of \(N\) in \(G\) is \[ N_G(N)=\{g\in G:gNg^{-1}=N\}. \] It is the largest subgroup of \(G\) in which \(N\) is normal. In particular, a subgroup \(H\leq G\) acts on \(N\) by conjugation precisely when \[ H\leq N_G(N). \] See [fre2023discrete, sec. 4.2.6, pp. 56--57].
The ambient group matters. If \(H\) normalizes \(N\), then \(N\) is normal in the subgroup generated by \(N\) and \(H\). This does not imply that \(N\) is normal in all of \(G\).
For the quaternion subgroups in Quaternion and order-three subgroups, the three conjugation calculations in the Hurwitz action on the quaternion group give \[ C\leq N_{\mathbb {H}^{\times }}(Q). \] They do not claim that \(Q\) is normal in \(\mathbb {H}^{\times }\).
Lemma. a normalized product is the generated subgroup [fgap-000G]AGENTDRAFTED
- July 28, 2026
Lemma. a normalized product is the generated subgroup [fgap-000G]AGENTDRAFTED
- July 28, 2026
Let \(N,H\leq G\). If \(H\leq N_G(N)\), then the set product \[ NH=\{nh:n\in N,\ h\in H\} \] is a subgroup and \[ N\vee H=NH. \] Moreover, \(N\) is normal in \(N\vee H\).
Proof.
- July 28, 2026
Proof.
- July 28, 2026
Normalization gives the calculation needed for closure: \[ (n_1h_1)(n_2h_2) =n_1(h_1n_2h_1^{-1})h_1h_2\in NH. \] It also gives \((nh)^{-1}=(h^{-1}n^{-1}h)h^{-1}\in NH\). Thus \(NH\) is a subgroup containing both \(N\) and \(H\), while every subgroup containing \(N\) and \(H\) contains every product \(nh\). This proves \(N\vee H=NH\). Finally, conjugation by generators from \(N\) and \(H\) preserves \(N\), so \(N\) is normal in their generated subgroup.
This is the small bridge between an action by conjugation and an internal product. Compare the normalizer and internal-product discussion in [fre2023discrete, secs. 4.2.6 and 4.2.13, pp. 56--57 and 62--63].
Definition. complementary subgroups [fgap-000H]AGENTDRAFTED
- July 28, 2026
Definition. complementary subgroups [fgap-000H]AGENTDRAFTED
- July 28, 2026
Subgroups \(N,H\leq G\) are complementary, in this ordered sense, when multiplication \[ N\times H\longrightarrow G,\qquad (n,h)\longmapsto nh \] is a bijection. Equivalently, every \(g\in G\) has a unique factorization \(g=nh\).
For subgroups, the two conditions \[ N\cap H=\{1\},\qquad NH=G \] give complementarity. Existence follows from \(NH=G\). For uniqueness, if \(n_1h_1=n_2h_2\), then \[ n_2^{-1}n_1=h_2h_1^{-1}\in N\cap H, \] so both sides are \(1\).
Trivial intersection alone is not enough: a complement must also provide the factorization of the ambient group. Fré uses these ingredients for an internal semidirect product in [fre2023discrete, sec. 4.2.13, pp. 62--63].
Theorem. the internal semidirect-product theorem [fgap-000I]AGENTDRAFTED
- July 28, 2026
Theorem. the internal semidirect-product theorem [fgap-000I]AGENTDRAFTED
- July 28, 2026
Let \(N,H\leq G\). Suppose \(N\) is normal in \(G\) and \(N,H\) are complementary. Conjugation defines an action \[ \alpha :H\longrightarrow \operatorname {Aut}(N),\qquad \alpha (h)(n)=hnh^{-1}. \] Give \(N\times H\) the multiplication \[ (n_1,h_1)(n_2,h_2) =\bigl (n_1\alpha (h_1)(n_2),h_1h_2\bigr ). \] The resulting external semidirect product is denoted \(N\rtimes _{\alpha }H\). Multiplication induces an isomorphism \[ N\rtimes _{\alpha }H\xrightarrow {\ \cong \ }G, \qquad (n,h)\longmapsto nh. \]
Proof.
- July 28, 2026
Proof.
- July 28, 2026
The displayed multiplication is chosen so that \[ (n_1h_1)(n_2h_2) =n_1(h_1n_2h_1^{-1})h_1h_2. \] Thus the multiplication map preserves products. Complementarity makes it bijective, so it is an isomorphism.
Conversely, the canonical copies of \(N\) and \(H\) in \(N\rtimes _{\alpha }H\) are complementary, and the copy of \(N\) is normal. The external multiplication and its split exact sequence are developed in [isaev2018theory, sec. 1.4.2, pp. 58--61]; compare [fre2023discrete, sec. 4.2.13, pp. 62--63]. An arbitrary extension by a normal subgroup need not split: the complement is extra structure.
Example. the binary tetrahedral subgroup of the quaternions [fgap-000J]AGENTDRAFTED
- July 28, 2026
Example. the binary tetrahedral subgroup of the quaternions [fgap-000J]AGENTDRAFTED
- July 28, 2026
Inside \(\mathbb {H}^{\times }\), let \[ T=Q\vee C. \] The Hurwitz action in the Hurwitz action on the quaternion group says that \(C\) normalizes \(Q\). Hence a normalized product is the generated subgroup gives \[ T=QC,\qquad Q\mathrel {\trianglelefteq }T. \]
The groups \(Q\) and \(C\) have orders 8 and 3. The order of their intersection divides both, so \[ Q\cap C=\{1\}. \] They are therefore complementary in \(T\). Every element has a unique normal form \[ q\omega ^r,\qquad q\in Q,\quad 0\leq r<3, \] and the internal semidirect-product theorem gives \[ Q\rtimes _{\alpha }C\cong T,\qquad \alpha (c)(q)=cqc^{-1}. \]
The action orientation is fixed by the quaternion calculation: \[ i\longmapsto k\longmapsto j\longmapsto i. \] Voight identifies this semidirect product with the Hurwitz unit group and the binary tetrahedral group in [voight2021quaternion, sec. 11.2.4, p. 168].
Example. the twenty-four Hurwitz units [fgap-000K]AGENTDRAFTED
- July 28, 2026
Example. the twenty-four Hurwitz units [fgap-000K]AGENTDRAFTED
- July 28, 2026
The unique normal forms divide \(T\) into three disjoint rows: \[ \begin {array}{c|c|c} Q&Q\omega &Q\omega ^2\\ \hline 8\text { elements}&8\text { elements}&8\text { elements}. \end {array} \] Therefore \(|T|=8\cdot 3=24\).
The first row is \[ Q=\{\pm 1,\pm i,\pm j,\pm k\}. \] Since \[ \omega =\frac {-1+i+j+k}{2},\qquad \omega ^2=\frac {-1-i-j-k}{2}, \] left multiplication by the 8 elements of \(Q\) gives \[ Q\omega \sqcup Q\omega ^2 = \left \{ \frac {\epsilon _0+\epsilon _1i+\epsilon _2j+\epsilon _3k}{2}: \epsilon _r\in \{\pm 1\} \right \}. \] The coordinates are distinct, so these are the 16 half-integral units. Together with \(Q\), they are exactly the 24 Hurwitz units listed in [voight2021quaternion, sec. 11.2, p. 166]. Thus the subgroup \(T\) is the unit group of the Hurwitz order, not merely another group of the same cardinality.
Remark. internal, external, and abstract models [fgap-000L]AGENTDRAFTED
- July 28, 2026
Remark. internal, external, and abstract models [fgap-000L]AGENTDRAFTED
- July 28, 2026
Three related objects have appeared. The internal model \(T\leq \mathbb {H}^{\times }\) has quaternions as its elements. The external semidirect product \(Q\rtimes _{\alpha }C\) has pairs \((q,c)\) as its elements. An abstract binary tetrahedral group can instead be specified without quaternion coordinates.
The isomorphism \((q,c)\mapsto qc\) compares the first two models. It is not an equality of their elements.
The next note transports the distinguished central involution and
cardinality to an abstract binary tetrahedral model. Transporting the full
factorization to factors such as QuaternionGroup 2 and
Multiplicative (ZMod 3) also needs explicit isomorphisms and
equivariance proofs. None of this follows from the order computation
\(|T|=24\) alone.
Definition. the distinguished involution of abstract 2T [fgap-0014]AGENTDRAFTED
Definition. the distinguished involution of abstract 2T [fgap-0014]AGENTDRAFTED
Let \(T\leq \mathbb {H}^{\times }\) be the binary tetrahedral group of Hurwitz units from the binary tetrahedral subgroup of the quaternions, and let \(B\) be the abstract semidirect-product model obtained from the same Hurwitz action. Choose the group isomorphism \[ \rho :B\mathbin {\cong }T \] that compares these two models. Voight identifies \(T\) with the Hurwitz unit group and with \(Q_8\rtimes \mathbb {Z}/3\mathbb {Z}\) in [voight2021quaternion, sec. 11.2.4, p. 168].
The quaternion \(-1\) belongs to \(T\); it is central, its square is 1, and it is not 1. Define the distinguished central involution of \(B\) by \[ z=\rho ^{-1}(-1). \] Since an isomorphism preserves multiplication and reflects equality, \[ z\in Z(B),\qquad z^2=1,\qquad z\neq 1. \] Thus the abstract group retains the central involution supplied by its quaternionic realization. The element \(z\) is not identified with the quaternion \(-1\); the isomorphism \(\rho \) relates them.
The same isomorphism transports cardinality. Since the calculation in
the twenty-four Hurwitz units gives \(|T|=24\),
\[
|B|=|T|=24.
\]
The corresponding Lean theorem uses Mathlib's Nat.card; its
statement is Nat.card BinaryTetrahedral.Abstract = 24.
The occurrence of \(-1\) among the 24 Hurwitz units is explicit in [voight2021quaternion, sec. 11.2, p. 166].
Central involutions and complementary summands [fgap-000V]AGENTDRAFTED
Central involutions and complementary summands [fgap-000V]AGENTDRAFTED
A central element whose square is one produces two complementary idempotents whenever two is invertible. The construction separates a module into the two eigenspaces of that element and separates the algebra itself into two algebra factors. No semisimplicity or representation classification is needed.
The reading order follows the implications \[ \begin {array}{ccccc} z^2=1,\ z\in Z(A)&\longrightarrow &e_+,e_-& \longrightarrow &M=e_+M\oplus e_-M\\ &&\big \downarrow &&\\ &&A\cong e_+A\times e_-A.&& \end {array} \] Centrality is needed for the lower algebra statement. The upper module decomposition is an additive direct sum from the complementary-idempotent equations; centrality makes its summands \(A\)-submodules.
Definition. central involution in an algebra [fgap-000W]AGENTDRAFTED
Definition. central involution in an algebra [fgap-000W]AGENTDRAFTED
Let \(R\) be a commutative ring, let \(A\) be an associative unital \(R\)-algebra, and suppose \(2\cdot 1_R\) is invertible. Write \[ h=(2\cdot 1_R)^{-1}. \] A central involution for this construction is an element \(z\in A\) such that \[ z^2=1_A,\qquad za=az\quad \text {for every }a\in A. \] We then define \[ e_+=h(1_A+z),\qquad e_-=h(1_A-z), \] using the structural map \(R\to A\) for the scalar \(h\).
Only the equation \(z^2=1_A\) is used. The element need not have exact order 2: the extra condition \(z\neq 1_A\) merely excludes the degenerate case \(e_-=0\). The algebra \(A\) need not be commutative.
Example. a central group element inside a Group Algebra [fgap-000X]AGENTDRAFTED
Example. a central group element inside a Group Algebra [fgap-000X]AGENTDRAFTED
Let \(G\) be a group and let \(z_G\in G\) satisfy \[ z_G^2=1_G,\qquad z_Gg=gz_G\quad \text {for every }g\in G. \] In the Group Algebra \(R[G]\), write \([z_G]\) for the basis element indexed by \(z_G\). Then \[ [z_G]^2=[1_G]=1_{R[G]}, \] and \([z_G]\) commutes with every basis element \([g]\). By linearity it is a central involution in the algebra. The Group Algebra and the passage from group representations to its modules are developed in [sengupta2010representations, secs. 3.1--3.3, pp. 39--42]; compare [webb2007finite, pp. 1--4].
The brackets matter. Assume \(R\) is nontrivial. Then \([z_G]\neq -1_{R[G]}\): their supports differ when \(z_G\neq 1_G\); when \(z_G=1_G\), this is \(1_{R[G]}\neq -1_{R[G]}\), since 2 is invertible.
Lemma. the two idempotents of a central involution [fgap-000Y]AGENTDRAFTED
Lemma. the two idempotents of a central involution [fgap-000Y]AGENTDRAFTED
For the elements \(e_+\) and \(e_-\) associated with a central involution, \[ e_+^2=e_+,\qquad e_-^2=e_-,\qquad e_+e_-=e_-e_+=0,\qquad e_++e_-=1_A. \] Both idempotents are central.
Proof.
Proof.
First, \[ e_++e_-=h(1+z)+h(1-z)=2h=1_A, \] so \(e_-=1_A-e_+\). Since \(2h=1_R\) and \(z^2=1_A\), \[ e_+^2 =h^2(1+2z+z^2) =2h^2(1+z) =e_+. \] The remaining identities now follow from this one idempotence calculation: \[ \begin {aligned} e_-^2&=(1_A-e_+)^2=1_A-e_+=e_-,\\ e_+e_-&=e_+(1_A-e_+)=0,\\ e_-e_+&=(1_A-e_+)e_+=0. \end {aligned} \] Finally, each \(e_\pm \) is a scalar linear combination of the central elements \(1_A\) and \(z\), so it is central.
These equations are the elementary two-idempotent instance of the projection calculus discussed in [sengupta2010representations, sec. 4.5, pp. 63--68].
Example. the central split of the real Group Algebra of 2T [fgap-0015]AGENTDRAFTED
Example. the central split of the real Group Algebra of 2T [fgap-0015]AGENTDRAFTED
Let \(B\) be the abstract binary tetrahedral group, let \(z\in B\) be its distinguished central involution, and put \[ A=\mathbb {R}[B]. \] The group element \(z\), its basis image \([z]\in A\), and the scalar \(-1_A\) are different kinds of objects. The image \([z]\) is central in \(A\) and satisfies \([z]^2=1_A\), by a central group element inside a Group Algebra.
The two elements \[ e_+=\frac {1_A+[z]}2,\qquad e_-=\frac {1_A-[z]}2 \] therefore satisfy \[ e_+^2=e_+,\qquad e_-^2=e_-,\qquad e_+e_-=e_-e_+=0,\qquad e_++e_-=1_A. \] They are central by the two idempotents of a central involution. Hence left multiplication by \(e_+\) and \(e_-\) gives two complementary projections on the regular \(A\)-module. This specializes the generic central-involution split to \(\mathbb {R}[B]\); no representation-theoretic classification is used.
The Group Algebra convention is developed in [sengupta2010representations, secs. 3.1--3.3, pp. 39--42]. The projection interpretation of complementary idempotents is compared with [webb2007finite, exercise 2.7, p. 15].
Theorem. the eigenspace decomposition of a module [fgap-000Z]AGENTDRAFTED
Theorem. the eigenspace decomposition of a module [fgap-000Z]AGENTDRAFTED
Let \(z\) be a central involution in \(A\), let \(e_+,e_-\) be its associated idempotents, and let \(M\) be a left \(A\)-module. Left multiplication defines \(A\)-linear projections \[ p_\pm :M\longrightarrow M,\qquad p_\pm (m)=e_\pm m. \] They satisfy \[ p_\pm ^2=p_\pm ,\qquad p_++p_-=\mathrm {id}_M,\qquad p_+p_-=p_-p_+=0. \] Their ranges and kernels are \[ \begin {aligned} \operatorname {range}(p_+)&=e_+M,& \ker (p_+)&=\operatorname {range}(p_-)=e_-M,\\ \operatorname {range}(p_-)&=e_-M,& \ker (p_-)&=\operatorname {range}(p_+)=e_+M. \end {aligned} \] Consequently, if \[ M_+=e_+M,\qquad M_-=e_-M, \] then \[ M=M_+\oplus M_-. \] These summands are precisely the two eigenspaces for the action of \(z\): \[ M_+=\{m\in M:zm=m\},\qquad M_-=\{m\in M:zm=-m\}. \]
Proof.
Proof.
The idempotent and mixed-product identities from the two idempotents of a central involution give the displayed projection identities after acting on \(M\). Centrality of \(e_\pm \) makes \(p_\pm \) \(A\)-linear. Their ranges are \(e_\pm M\) by definition. If \(p_+(m)=0\), then \[ m=(p_++p_-)(m)=p_-(m), \] so \(m\) lies in the range of \(p_-\). Conversely, \(p_+p_-=0\) shows that every element in that range lies in \(\ker (p_+)\). This proves the first kernel-range equality; the second is symmetric. The identity \(p_++p_-=\mathrm {id}_M\) now gives the displayed direct sum.
Direct calculation gives \(ze_+=e_+\) and \(ze_-=-e_-\), proving one eigenspace inclusion in each case. Conversely, if \(zm=m\), then \[ e_+m=h(m+zm)=2hm=m. \] If \(zm=-m\), the analogous calculation gives \(e_-m=m\).
Idempotents as projections and complementary orthogonal idempotents as direct decompositions are recorded in [webb2007finite, exercise 2.7, p. 15]; see also [sengupta2010representations, props. 4.5.1--4.5.3, pp. 63--67].
Theorem. the central-idempotent algebra product [fgap-0010]AGENTDRAFTED
Theorem. the central-idempotent algebra product [fgap-0010]AGENTDRAFTED
For a central involution \(z\) and its associated idempotents, put \[ A_+=e_+A,\qquad A_-=e_-A. \] Because \(e_+\) and \(e_-\) are central, these are two-sided ideals and \(e_\pm A=Ae_\pm \). Each is a unital \(R\)-algebra in its own right, with unit \(e_\pm \) and structural map \(r\mapsto re_\pm \). There is an \(R\)-algebra isomorphism \[ \begin {aligned} \Phi :A&\longrightarrow A_+\times A_-, &a&\longmapsto (e_+a,e_-a),\\ \Psi :A_+\times A_-&\longrightarrow A, &(x,y)&\longmapsto x+y. \end {aligned} \]
Proof.
Proof.
For \(a,b\in A\), \(a(e_\pm b)=e_\pm (ab)\) and \((e_\pm b)a=e_\pm (ba)\), so \(A_\pm \) are two-sided ideals. If \(x=e_+a\in A_+\), then \(e_+x=x\); thus \(e_+\) is the unit of \(A_+\), and similarly for \(A_-\).
Mixed products vanish: \[ (e_+a)(e_-b)=e_+e_-ab=0, \] and likewise in the reverse order. It follows that \(\Phi \) and \(\Psi \) preserve multiplication. Finally, \[ \Psi \Phi (a)=(e_++e_-)a=a, \] while \(\Phi \Psi (x,y)=(x,y)\) because the matching idempotent fixes each factor and the other annihilates it.
The use of local units on idempotent-generated ideals follows the standard discussion in [sengupta2010representations, secs. 4.5--4.6, pp. 63--73].
Example. splitting the Group Algebra of C₂ [fgap-0011]AGENTDRAFTED
Example. splitting the Group Algebra of C₂ [fgap-0011]AGENTDRAFTED
Let \(C_2=\{1,s\}\) with \(s^2=1\), and suppose 2 is invertible in the nonzero commutative ring \(R\). The basis element \([s]\) is central, and \[ e_+=\frac {[1]+[s]}2,\qquad e_-=\frac {[1]-[s]}2. \] The algebra-product theorem becomes \[ R[C_2]\cong R\times R. \]
The isomorphism and its inverse are explicit: \[ \begin {aligned} a[1]+b[s]&\longmapsto (a+b,a-b),\\ (x,y)&\longmapsto \frac {x+y}{2}[1]+\frac {x-y}{2}[s]. \end {aligned} \] Under this map, \(e_+\) goes to \((1,0)\) and \(e_-\) goes to \((0,1)\). Thus the two idempotents are the coordinate projections, not merely a dimension count.
Remark. three levels of splitting [fgap-0012]AGENTDRAFTED
Remark. three levels of splitting [fgap-0012]AGENTDRAFTED
The same formulas support three conclusions, but their structures should not be conflated: \[ \begin {array}{c|c|c} \text {level}&\text {conclusion}&\text {input}\\ \hline \text {additive}&M=e_+M\oplus e_-M& e_++e_-=1,\ e_+e_-=e_-e_+=0\\ \text {module}&M_\pm \text { are eigensubmodules}& \text {central action of }z\\ \text {algebra}&A\cong e_+A\times e_-A& e_+,e_-\text { central}. \end {array} \]
For an arbitrary idempotent \(e\in A\), left multiplication by \(e\) and \(1-e\) gives a split of the underlying \(R\)-module, \[ A=eA\oplus (1-e)A, \] and therefore also of the underlying additive group. Without centrality, these projections need not be homomorphisms of the left regular \(A\)-module: \(eA\) and \((1-e)A\) are right ideals, but need not be left ideals or two-sided ideals. The two summands therefore need not be algebra factors. The product theorem is stronger than this \(R\)-module direct-sum statement.
Remark. mathematical summands and physical readings [fgap-0013]AGENTDRAFTED
Remark. mathematical summands and physical readings [fgap-0013]AGENTDRAFTED
A central involution canonically separates the algebra and its modules into two mathematical summands. This alone does not identify either summand with particles, interactions, chirality, or any other physical sector. Such an interpretation requires additional data: a representation, selected observables or forms, dynamics, and a map from the mathematics to measurable quantities.
The split is useful precisely because it can be calculated before those choices are made. Later notes may test proposed physical correspondences against it, but the algebra decomposition remains valid independently of whether any such proposal succeeds.
Real blocks of the quaternion Group Algebra [fgap-001C]AGENTDRAFTED
- July 30, 2026
- Utensil Song
Real blocks of the quaternion Group Algebra [fgap-001C]AGENTDRAFTED
- July 30, 2026
- Utensil Song
The preceding central-involution construction isolates algebra factors without classifying all representations. For the quaternion group, the following direct coefficient calculation goes further and makes every real block explicit.
Proposition. the real Group Algebra of the quaternion group [fgap-001B]AGENTDRAFTED
Proposition. the real Group Algebra of the quaternion group [fgap-001B]AGENTDRAFTED
Let \(Q_8=\{\pm 1,\pm i,\pm j,\pm k\}\) be the concrete quaternion group from the quaternion group inside Hamilton's Quaternions, and put \[ \mathcal {E}=\{-1,1\}\subset \mathbb {R}^{\times }, \qquad \mathcal {X}=\mathcal {E}\times \mathcal {E}. \] For \((\epsilon ,\delta )\in \mathcal {X}\), there is a real character \[ \chi _{\epsilon ,\delta }:Q_8\longrightarrow \mathbb {R}^{\times } \] determined by \[ \chi _{\epsilon ,\delta }(-1)=1,\qquad \chi _{\epsilon ,\delta }(i)=\epsilon ,\qquad \chi _{\epsilon ,\delta }(j)=\delta ,\qquad \chi _{\epsilon ,\delta }(k)=\epsilon \delta . \] These are the four characters pulled back from \(Q_8/\{\pm 1\}\cong C_2\times C_2\); compare [etingof2024introduction, sec. 4.3, pp. 63--64 and ex. 4.8.1, p. 73].
Write \(\mathbb {R}^{\mathcal {X}}\) for the algebra of functions \(\mathcal {X}\to \mathbb {R}\), with pointwise operations. Extending the four characters and the inclusion \(Q_8\subset \mathbb {H}^{\times }\) linearly gives an algebra homomorphism \[ \Phi :\mathbb {R}[Q_8]\longrightarrow \mathbb {R}^{\mathcal {X}}\times \mathbb {H}. \] Then \(\Phi \) is an isomorphism of real algebras. The displayed map retains the chosen character index and quaternionic realization as part of its data.
Proof.
Proof.
Let \(u_q\) be the Group-Algebra basis element indexed by \(q\in Q_8\).
Write a general element in the form \[ x=\sum _{q\in Q_8}a_qu_q. \] For \(q\in \{1,i,j,k\}\), set \[ s_q=a_q+a_{-q},\qquad d_q=a_q-a_{-q}. \] The quaternion coordinate of \(\Phi (x)\) is \[ d_1+d_i i+d_j j+d_k k. \] It therefore recovers the four differences \(d_q\).
The coordinate indexed by \((\epsilon ,\delta )\in \mathcal {X}\) is \[ y_{\epsilon ,\delta } =s_1+\epsilon s_i+\delta s_j+\epsilon \delta s_k. \] The inverse Hadamard calculation gives \[ \begin {aligned} s_1&=\frac 14\sum _{(\epsilon ,\delta )\in \mathcal {X}}y_{\epsilon ,\delta },& s_i&=\frac 14\sum _{(\epsilon ,\delta )\in \mathcal {X}} \epsilon y_{\epsilon ,\delta },\\ s_j&=\frac 14\sum _{(\epsilon ,\delta )\in \mathcal {X}} \delta y_{\epsilon ,\delta },& s_k&=\frac 14\sum _{(\epsilon ,\delta )\in \mathcal {X}}\epsilon \delta y_{\epsilon ,\delta }. \end {aligned} \] Thus the four real coordinates recover the four sums \(s_q\). Finally, \[ a_q=\frac {s_q+d_q}{2},\qquad a_{-q}=\frac {s_q-d_q}{2}, \] so \(\Phi (x)\) recovers all eight coefficients of \(x\). Hence \(\Phi \) is injective. Its domain and codomain both have real dimension 8, so it is bijective.
The quaternion coordinate alone is surjective, because its basis values include \(1,i,j,k\). It vanishes exactly when \(d_1=d_i=d_j=d_k=0\), or equivalently when \(a_q=a_{-q}\) for \(q\in \{1,i,j,k\}\). Its kernel is therefore the 4-dimensional span of \[ u_1+u_{-1},\quad u_i+u_{-i},\quad u_j+u_{-j},\quad u_k+u_{-k}. \] It therefore induces \[ \mathbb {R}[Q_8]/\ker (\Phi _{\mathbb {H}}) \cong _{\mathbb {R}\text {-alg}}\mathbb {H}. \] This quotient depends on the chosen quaternionic realization. The combined map \(\Phi \) is what exhibits the selected quotient as the quaternion factor of the displayed product; a quotient map by itself does not supply that direct-factor statement.
The quaternion model is grounded in [voight2021quaternion, sec. 11.2, p. 166]. The extension of group representations to Group-Algebra maps follows [sengupta2010representations, secs. 3.1--3.2, pp. 39--41]. The coefficient recovery above is direct and does not assume a general classification theorem. No physical meaning is assigned to a factor merely from its dimension or familiar algebra.
Appendix [fgap-001A]AGENTDRAFTED
- with contributions from Utensil Song
Appendix [fgap-001A]AGENTDRAFTED
- with contributions from Utensil Song
The appendix first supplies the general Group-Algebra route behind the finite examples. It then records exploratory structures that are not needed for the quaternionic and Group-Algebra spine.
The human-curated Group-Algebra route [fgap-001G]
📄PDFAGENTDRAFTED
- August 12, 2026
- Utensil Song
The human-curated Group-Algebra route [fgap-001G]
📄PDFAGENTDRAFTED
- August 12, 2026
- Utensil Song
A finite group becomes linear once its elements are used as a basis. This route starts with that construction, passes through modules, semisimple blocks, and characters, and then follows normal subgroups, computation, and twisted multiplication. The explicit quaternion calculations earlier in these notes are test cases for this general route, not substitutes for it.
Definition. the Group Algebra and its universal extension [fgap-001H]
L∃∀NAGENTDRAFTED
Definition. the Group Algebra and its universal extension [fgap-001H]
L∃∀NAGENTDRAFTED
Let \(k\) be a commutative ring and \(G\) a group. The Group Algebra \(k[G]\) is the free \(k\)-module with basis \([g]\) indexed by \(g\in G\), equipped with \[ [g][h]=[gh],\qquad 1=[1_G],\qquad (\sum _g a_g[g])(\sum _h b_h[h])=\sum _{g,h}a_gb_h[gh]. \] The scalar embedding sends \(a\) to \(a[1_G]\). Thus each group element is a unit of \(k[G]\), with inverse \([g^{-1}]\).
If \(A\) is a \(k\)-algebra and \(u:G\to A^\times \) is a group homomorphism, there is a unique \(k\)-algebra homomorphism \[ \widetilde u:k[G]\longrightarrow A, \qquad \widetilde u\left (\sum _g a_g[g]\right )=\sum _g a_g u(g). \] This universal property extends representations and concrete group maps from basis elements to the whole Group Algebra. See [sengupta2010representations, secs. 3.1--3.2, pp. 39--41].
Theorem. representations are Group-Algebra modules [fgap-001I]
Theorem. representations are Group-Algebra modules [fgap-001I]
Let \(k\) be a field, \(G\) a group, and \(V\) a \(k\)-vector space. Giving a linear representation \(\rho :G\to \operatorname {GL}_k(V)\) is equivalent to giving a unital left \(k[G]\)-module structure on \(V\), up to the identity type synonyms used to keep the 2 scalar actions distinct. The action associated to \(\rho \) is \[ (\sum _g a_g[g])\cdot v=\sum _g a_g\rho (g)v. \] Conversely, restriction of a unital \(k[G]\)-action to the units \([g]\) recovers \(\rho \). Invariant subspaces are submodules and intertwining linear maps are \(k[G]\)-linear maps.
Proof.
Proof.
The extension in the Group Algebra and its universal extension supplies the algebra homomorphism \(k[G]\to \operatorname {End}_k(V)\). Associativity and the unit law give a module. In the other direction, multiplication by each \([g]\) is invertible, and the module law gives the group law. These operations are inverse. See [sengupta2010representations, sec. 3.2, pp. 40--41].
Example. the regular representation reads the basis [fgap-001J]AGENTDRAFTED
Example. the regular representation reads the basis [fgap-001J]AGENTDRAFTED
Let \(G\) act on \(k[G]\) by left multiplication. In the basis \(\{[h]:h\in G\}\), an element \(g\) sends \([h]\) to \([gh]\); hence its matrix is the permutation matrix of left translation. This is the left regular representation. It is faithful because the image of \([1_G]\) records \(g\).
The same basis underlies the coefficient calculations in the real Group Algebra of the quaternion group: there, the quaternion coordinate recovers antisymmetric coefficient pairs and the character coordinates recover symmetric pairs. The regular module is the linear carrier for both the abstract Group Algebra and the explicit 8-coordinate computation. Compare [james2001representations, ch. 6, pp. 53--58].
Theorem. Maschke averaging [fgap-001K]
L∃∀NAGENTDRAFTED
Theorem. Maschke averaging [fgap-001K]
L∃∀NAGENTDRAFTED
Let \(G\) be finite and \(k\) a field in which \(|G|\) is invertible. Every subrepresentation \(W\subseteq V\) has a \(G\)-stable complement. Consequently every finite-dimensional \(k[G]\)-module, and \(k[G]\) itself, is semisimple.
Proof.
Proof.
Choose a \(k\)-linear projection \(P:V\to W\) and average its conjugates: \[ P_G=\frac 1{|G|}\sum _{g\in G}\rho (g)P\rho (g)^{-1}. \] Then \(P_G\) remains the identity on \(W\) and commutes with \(G\). Its kernel is a \(G\)-stable complement. Division by \(|G|\) requires the stated invertibility hypothesis. This is Maschke's theorem as proved in [sengupta2010representations, thm. 3.5.1, pp. 44-46].
Theorem. Wedderburn blocks over an algebraically closed field [fgap-001L]
L∃∀NAGENTDRAFTED
Theorem. Wedderburn blocks over an algebraically closed field [fgap-001L]
L∃∀NAGENTDRAFTED
Let \(G\) be finite and \(k\) an algebraically closed field whose characteristic does not divide \(|G|\). There are positive integers \(d_C\), indexed by the conjugacy classes \(C\) of \(G\), such that \[ k[G]\cong _{k\text {-alg}} \prod _{C\in \operatorname {Conj}(G)}M_{d_C}(k), \qquad \sum _C d_C^2=|G|. \] The class labels are an indexing choice: the statement does not canonically pair a particular conjugacy class with a particular irreducible module.
Maschke semisimplicity followed by Artin--Wedderburn gives the stated product. Lux and Pahlings state the results in [lux2010representations, thms. 1.5.5--1.5.6, pp. 56--57].
The dimension identity can also be read from the regular representation, where an irreducible module occurs with multiplicity equal to its dimension; compare [james2001representations, thms. 11.9 and 11.12, pp. 100--101].
Definition. characters, class functions, and the character table [fgap-001M]
Definition. characters, class functions, and the character table [fgap-001M]
For a finite-dimensional representation \(\rho \) over a
characteristic-zero field, its character is
\(\chi _\rho (g)=\operatorname {tr}(\rho (g))\). Trace is unchanged by
conjugation, so \(\chi _\rho \) is a class function. A character
table places the irreducible characters in rows and the conjugacy classes in
columns. Tau Ceti identifies class functions with functions on conjugacy
classes in
TauCeti.ClassFunction.equivConjClasses.
Over \(\mathbb C\), the irreducible characters form an orthonormal basis of the class functions. Thus the table is square: the number of irreducible characters equals the number of conjugacy classes. This also counts the Wedderburn blocks and gives the dimension of the center. See [james2001representations, thm. 16.4, pp. 159--166].
Theorem. primitive central idempotents as block projectors [fgap-001N]
Theorem. primitive central idempotents as block projectors [fgap-001N]
Over a splitting field of characteristic not dividing \(|G|\), an irreducible character \(\chi \) defines the central element \[ e_\chi =\frac {\chi (1)}{|G|}\sum _{g\in G}\chi (g^{-1})[g]. \] It is a nonzero primitive central idempotent. On a simple module with character \(\psi \), it acts as the identity if \(\psi =\chi \) and as zero otherwise. Distinct \(e_\chi \) are therefore orthogonal block projectors. See [lux2010representations, thm. 2.1.6 and cor. 2.1.7, pp. 88-90]. A constructed family of such projectors does not yield a complete block decomposition until a sum-to-1 statement is also known.
Theorem. the Frobenius-Schur trichotomy [fgap-0021]
Theorem. the Frobenius-Schur trichotomy [fgap-0021]
Let \(\rho \) be an irreducible finite-dimensional representation of a finite group over an algebraically closed field of characteristic 0. Its Frobenius-Schur indicator \[ \nu _2(\rho )=\frac 1{|G|}\sum _{g\in G}\chi _\rho (g^2) \] takes exactly 1 of the values \(1\), \(0\), and \(-1\). The value \(1\) is equivalent to the existence of a nondegenerate invariant symmetric bilinear form; \(-1\) is equivalent to a nondegenerate invariant alternating form; and \(0\) is equivalent to the absence of a nonzero invariant bilinear form. See [james2001representations, def. 23.13, the proof of thm. 23.14, and thm. 23.16, pp. 273-277]. James and Liebeck state the alternatives using nonzero invariant forms; for an irreducible representation, a nonzero invariant symmetric or alternating form has zero radical and is therefore nondegenerate.
This trichotomy classifies the invariant-form behavior of the complex irreducible representation. It does not by itself compute a Schur index or a complete decomposition after descent to \(\mathbb R\).
Remark. real types are not Schur indices [fgap-001Y]AGENTDRAFTED
Remark. real types are not Schur indices [fgap-001Y]AGENTDRAFTED
Over \(\mathbb R\), a simple finite-dimensional block may instead have division algebra \(\mathbb R\), \(\mathbb C\), or \(\mathbb H\). The Frobenius--Schur trichotomy in the Frobenius-Schur trichotomy detects invariant-form type, but it is not a complete theorem about a character's field of values or Schur index. The explicit decomposition \[ \mathbb R[Q_8]\cong \mathbb R^4\times \mathbb H \] in the real Group Algebra of the quaternion group is a complete real example, not an application of the algebraically closed formula. For Schur indices and invariant forms, see [lux2010representations, sec. 2.9, pp. 164--172].
Definition. conjugate constituents and the inertia subgroup [fgap-001O]AGENTDRAFTED
Definition. conjugate constituents and the inertia subgroup [fgap-001O]AGENTDRAFTED
Let \(N\trianglelefteq G\), let \(V\) be a \(G\)-representation, and let \(W\subseteq V|_N\) be an irreducible \(N\)-subrepresentation. For \(g\in G\), the conjugate representation \(,{}^gW\) has the same vector space and action \[ n\cdot _g w=(g^{-1}ng)\cdot w. \] The inertia subgroup of \(W\) is \[ I_G(W)=\{g\in G:{}^gW\cong W\}. \] The isomorphism classes of conjugates form a \(G\)-orbit, with stabilizer \(I_G(W)\). See [lux2010representations, sec. 3.6, pp. 222--225].
Theorem. the single orbit in Clifford restriction [fgap-001P]
Theorem. the single orbit in Clifford restriction [fgap-001P]
Let \(N\trianglelefteq G\) be finite, and work over a field for which the relevant finite-group modules are semisimple. If \(V\) is an irreducible \(G\)-representation, then the irreducible constituents of \(V|_N\) lie in 1 \(G\)-orbit under conjugation. Equivalently, after choosing 1 constituent \(W\), every other constituent is isomorphic to some \(,{}^gW\).
This is the orbit assertion in Clifford theory. It does not by itself say that all constituents occur with the same multiplicity, nor does it construct extensions across the inertia subgroup. Compare [lux2010representations, thm. 3.6.2(a), pp. 223--225].
Theorem. Clifford homogeneity and the semidirect route [fgap-001Q]AGENTDRAFTED
Theorem. Clifford homogeneity and the semidirect route [fgap-001Q]AGENTDRAFTED
Let \(N\trianglelefteq G\) and let \(V\) be an irreducible complex representation of \(G\). If \(W_1,\ldots ,W_r\) represent the distinct conjugates of an irreducible constituent of \(V|_N\), then for 1 positive integer \(e\), \[ V|_N\cong e(W_1\oplus \cdots \oplus W_r). \] Thus restriction is homogeneous along a single orbit. The common multiplicity is an additional assertion beyond the single orbit in Clifford restriction. This is Clifford's theorem, [james2001representations, thm. 20.8, pp. 216--217].
The inertia subgroup is the intermediate group where one studies whether \(W\) extends, possibly projectively, before inducing to \(G\). For semidirect products, this reduces the problem to the action of the complement. For \(Q_8\rtimes C_3\cong 2T\), it connects the normal quaternion subgroup to the skew-Group-Algebra model in two routes from binary tetrahedral symmetry. This theorem does not supply the full character table of \(2T\).
Example. semidirect products make Clifford theory concrete [fgap-0020]AGENTDRAFTED
Example. semidirect products make Clifford theory concrete [fgap-0020]AGENTDRAFTED
Suppose \(G=N\rtimes H\). Conjugation by \(H\) permutes the irreducible constituents of \(V|_N\). Their stabilizers are the inertia subgroups, so the orbit and homogeneity statements in the single orbit in Clifford restriction and Clifford homogeneity and the semidirect route reduce the search for irreducible \(G\)-representations to stabilizer data, projective extension, and induction. Clifford theory thereby gives a character-theoretic route for semidirect products.
For \(Q_8\rtimes C_3\cong 2T\), the action and ordinary skew-Group-Algebra realization are recorded in the central split of the real Group Algebra of 2T and two routes from binary tetrahedral symmetry. They supply the normal-subgroup and algebraic input to this route, but do not give the full character table of \(2T\).
Remark. from a presentation to checked representation data [fgap-001R]AGENTDRAFTED
Remark. from a presentation to checked representation data [fgap-001R]AGENTDRAFTED
A finite presentation \(\langle x_1,\ldots ,x_m\mid r_1,\ldots ,r_s\rangle \) gives a compact input for algorithms that enumerate cosets, compute conjugacy classes, and build character data. Sims develops the algorithms and the conditions under which such computations terminate; Lux and Pahlings place them inside computational representation theory.
The output has 3 possible evidential strengths. A transcript with versioned inputs is reproducible. A compact certificate, such as matrices satisfying the relations together with independently checked completeness identities, can be verified without trusting the search. An unrecorded software answer is neither. GAP is therefore a discovery and calculation tool; its output becomes mathematics here only when the decisive relations and completeness checks are visible. See [sims1994computation, ch. 1] and [lux2010representations, secs. 1.1 and 4.2].
The route is \[ \begin {aligned} \text {finite presentation}&\longrightarrow \text {computed candidates}\\ &\longrightarrow \text {checked relations and completeness}. \end {aligned} \] The arrows distinguish generation from certification rather than describing a project workflow.
Definition. factor sets and twisted Group Algebras [fgap-001S]
L∃∀NAGENTDRAFTED
Definition. factor sets and twisted Group Algebras [fgap-001S]
L∃∀NAGENTDRAFTED
Let \(k\) be a field, \(G\) a group, and \(\alpha :G\times G\to k^\times \) a normalized 2-cocycle: \[ \alpha (1,g)=\alpha (g,1)=1, \qquad \alpha (g,h)\alpha (gh,\ell )= \alpha (h,\ell )\alpha (g,h\ell ). \] The twisted Group Algebra \(k_\alpha [G]\) has basis \(u_g\) and multiplication \[ u_gu_h=\alpha (g,h)u_{gh}. \] The cocycle equation is exactly the associativity condition.
A projective representation with factor set \(\alpha \), namely operators \(T_g\) satisfying \(T_gT_h=\alpha (g,h)T_{gh}\), extends uniquely to an algebra map \(k_\alpha [G]\to \operatorname {End}_k(V)\); conversely an algebra map gives such a projective representation on its basis operators. Cohomologous cocycles rescale the basis and give isomorphic twisted algebras. See [conlon1964twisted, the introduction and sec. 1, pp. 152--155].
Remark. the qualified Clifford bridge [fgap-001Z]AGENTDRAFTED
Remark. the qualified Clifford bridge [fgap-001Z]AGENTDRAFTED
A generalized Clifford algebra becomes a twisted group algebra only after its parameters are fixed. Let \(k\) contain a primitive \(n\)-th root of unity \(\omega \), assume \(\operatorname {char}k\nmid n\), and choose \(q_1,\ldots ,q_m\in k^\times \). The algebra generated by \(e_1,\ldots ,e_m\) with \[ e_i^n=q_i, \qquad e_i e_j=\omega e_j e_i\quad (j<i) \] is isomorphic to a twisted group algebra of \((\mathbb Z/n\mathbb Z)^m\) for an explicit 2-cocycle. The monomials in the \(e_i\) correspond to its twisted basis. See [cheng2019new, sec. 2.3 and prop. 2.1, pp. 3--4].
This is a qualified bridge, not an identification of every Clifford algebra with an ordinary Group Algebra. The field, root of unity, grading, parameters, and twisting are part of the theorem. It is also different from Clifford theory in the single orbit in Clifford restriction and Clifford homogeneity and the semidirect route, which concerns restriction of representations to normal subgroups.
Remark. the inertia obstruction is projective [fgap-001T]AGENTDRAFTED
Remark. the inertia obstruction is projective [fgap-001T]AGENTDRAFTED
For a constituent \(W\) with inertia subgroup \(I=I_G(W)\), choose intertwiners \(T_i:W\to {}^iW\). Their composites need not satisfy the group law strictly. Instead one obtains scalars \[ T_iT_j=\alpha (i,j)T_{ij}. \] Associativity makes \(\alpha \) a factor set. Changing the intertwiners changes \(\alpha \) by a coboundary. The resulting cohomology class measures the obstruction to replacing the projective action by an ordinary action.
Twisted Group Algebras therefore enter the Clifford-theory route. The ordinary skew Group Algebra in two routes from binary tetrahedral symmetry corresponds to trivial twisting; it should not be identified with a general \(k_\alpha [G]\). The extension and induction analysis is developed in [lux2010representations, secs. 3.6--3.7, pp. 222--240].
Proposition. the canonical grading of a Group Algebra [fgap-001U]
Proposition. the canonical grading of a Group Algebra [fgap-001U]
For each \(g\in G\), let \(A_g=k[g]\) be the 1-dimensional subspace spanned by the basis element \([g]\). Then \[ k[G]=\bigoplus _{g\in G}A_g, \qquad A_gA_h\subseteq A_{gh}. \] Thus \(k[G]\) is canonically graded by the group \(G\). In Lean's additive graded-algebra interface this statement is expressed after passing from the multiplicative index \(G\) to its additive copy; each single basis element lies in its corresponding grade.
The basis and multiplication law in the Group Algebra and its universal extension give the decomposition and product containment directly; compare the construction in [sengupta2010representations, secs. 3.1--3.2, pp. 39--41]. It is distinct from the Hopf structure in the standard Hopf structure on a Group Algebra: the grading records where products land, while the coalgebra maps record how a basis element is copied and inverted.
Proposition. the standard Hopf structure on a Group Algebra [fgap-001V]
Proposition. the standard Hopf structure on a Group Algebra [fgap-001V]
Let \(k\) be a commutative ring and \(G\) a group. The Group Algebra \(k[G]\) is a Hopf algebra with structure determined on basis elements by \[ \Delta ([g])=[g]\otimes [g],\qquad \epsilon ([g])=1,\qquad S([g])=[g^{-1}]. \] The comultiplication and counit are algebra homomorphisms; the antipode extends inversion and satisfies the 2 convolution identities.
Proof.
Proof.
Each formula respects multiplication on basis elements. For example, \(\Delta ([gh])=[gh]\otimes [gh]=([g]\otimes [g])([h]\otimes [h])\). The counit calculation is similar. Finally \([g][g^{-1}]=[1]=[g^{-1}][g]\), which gives both antipode identities on the basis and hence by linearity on all of \(k[G]\). This group-algebra Hopf structure appears, for example, in [broue2024rings, ex. 18.3.3(1), pp. 500--501].
Remark. what the real quaternion example settles [fgap-001W]AGENTDRAFTED
Remark. what the real quaternion example settles [fgap-001W]AGENTDRAFTED
The general route has several distinct endpoints. Over an algebraically closed field, Wedderburn blocks and the character table organize all simple representations. Over \(\mathbb R\), division-algebra type and descent data enter. For a normal subgroup, Clifford theory organizes restriction and induction. With a nontrivial factor set, projective representations are modules over a twisted algebra.
The quaternion calculation in the real Group Algebra of the quaternion group closes 1 bounded endpoint: it gives an explicit real-algebra equivalence \(\mathbb R[Q_8]\cong \mathbb R^4\times \mathbb H\), and Real blocks of the quaternion Group Algebra identifies its center. It does not prove a general real Wedderburn theorem, the characters of \(2T\), or the Clifford-theory extension step. Those are separate statements and do not follow from the worked example.
Remark. the Hessian-group outlook [fgap-001X]AGENTDRAFTED
Remark. the Hessian-group outlook [fgap-001X]AGENTDRAFTED
Wilson's proposed route begins with \[ Q_8\rtimes C_3\cong 2T \] and then studies the iterated semidirect product \((G_{27}\rtimes Q_8)\rtimes C_3\), with the indicated actions part of the data. Its central scalar subgroup \(C_3\leq G_{27}\) has quotient the Hessian group of order 216, so the larger group is a triple cover of that quotient. The name alone would not choose either semidirect action. See [wilson2024discrete, sec. 2.2, pp. 4--5].
The comparison with \(U(1)\times SU(2)\times SU(3)\) is an attributed finite-model proposal, not an isomorphism or a canonical physical interpretation. To become a mathematical correspondence it would need typed representations and homomorphisms, the preserved forms or observables, and a rule connecting them to physical data. Hamilton's geometric-algebra models in [hamilton2023supergeometric] and [hamilton2023unification] provide a comparison motivation, not independent confirmation of this finite-group construction.
Finite tests for a topos layer [fgap-000M]AGENTDRAFTED
Finite tests for a topos layer [fgap-000M]AGENTDRAFTED
Group Actions, Group Algebras, and action groupoids already describe much of the finite symmetry data needed in these notes. The question here is narrower: does passing to a topos add universal classification, a common inverse-image language, or internal reasoning that is not already present below the topos level?
Five finite tests give a guarded answer. Ordinary actions and action groupoids do not need topoi. Torsor classification, inverse-image constructions, and internal inhabitation do add something, but only when their extra structure is actually used. Questions about local and global symmetry motivate these tests; they do not decide them.
Example. the real Group Algebra of a cyclic group of order three [fgap-000N]AGENTDRAFTED
Example. the real Group Algebra of a cyclic group of order three [fgap-000N]AGENTDRAFTED
Let \(C_3=\langle g\mid g^3=1\rangle \). Sending \(g\) to \(x\) gives \[ \mathbb {R}[C_3]\cong \mathbb {R}[x]/(x^3-1). \] Over the real numbers, \[ x^3-1=(x-1)(x^2+x+1), \] and the two factors are coprime. The Chinese remainder theorem and the identification \(\mathbb {R}[x]/(x^2+x+1)\cong \mathbb {C}\) therefore give \[ \mathbb {R}[C_3]\cong \mathbb {R}\times \mathbb {C}. \]
More concretely, if \(\zeta \) is a primitive complex cube root of unity, the isomorphism is \[ a+bg+cg^2\longmapsto \bigl (a+b+c,\ a+b\zeta +c\zeta ^2\bigr ). \] The two factors can be read in three compatible ways: \[ \begin {array}{c|c|c} \text {factor of }x^3-1& \text {real algebra block}& \text {real representation}\\ \hline x-1&\mathbb {R}&\text {trivial line}\\ x^2+x+1&\mathbb {C}&\text {rotation plane}. \end {array} \] The rotation plane is the linearization of the nontrivial part of the regular Group Action. More explicitly, the generator cyclically permutes the basis \(1,g,g^2\). The averaging element \[ e_0=\frac {1+g+g^2}{3} \] projects onto the fixed line \(\mathbb {R}(1+g+g^2)\), while its complementary kernel is the augmentation plane \[ \{a+bg+cg^2:a+b+c=0\}. \] Orbits, freeness, and transitivity belong to the action; the projector and invariant subspaces appear only after linearization.
Since the spectrum of a product is the disjoint union of the spectra, \[ \operatorname {Spec}\mathbb {R}[C_3] \cong \operatorname {Spec}\mathbb {R} \sqcup \operatorname {Spec}\mathbb {C}. \] This is a useful commutative picture. It is not yet a reason to introduce a topos, and it does not extend without choices to noncommutative Group Algebras.
Remark. the center is a commutative shadow [fgap-000O]AGENTDRAFTED
Remark. the center is a commutative shadow [fgap-000O]AGENTDRAFTED
The quaternion group \(Q_8\) has a real Group Algebra decomposition \[ \mathbb {R}[Q_8]\cong \mathbb {R}^4\times \mathbb {H}. \] This can be seen directly from the concrete copy \(Q_8\subset \mathbb {H}^{\times }\) in the quaternion group inside Hamilton's Quaternions, rather than assumed from a classification theorem.
Let \(u_q\) denote the basis element of the Group Algebra indexed by \(q\in Q_8\), and write a general element as \(x=\sum _{q\in Q_8}a_qu_q\). The four characters of \(Q_8/\{\pm 1\}\cong C_2\times C_2\) and the quaternionic map \(u_q\mapsto q\) combine to an algebra homomorphism \[ \Phi :\mathbb {R}[Q_8]\longrightarrow \mathbb {R}^4\times \mathbb {H}. \] For \(q\in \{1,i,j,k\}\), put \(s_q=a_q+a_{-q}\) and \(d_q=a_q-a_{-q}\). The quaternion coordinate of \(\Phi \) recovers \[ d_1+d_i i+d_j j+d_k k. \] The four real coordinates recover the Hadamard transform \[ s_1+\epsilon s_i+\delta s_j+\epsilon \delta s_k, \qquad \epsilon ,\delta \in \{\pm 1\}. \] The Hadamard matrix is invertible, so these four values recover every \(s_q\). Together with the four differences, they recover every coefficient. Thus \(\Phi \) has zero kernel. Both sides have real dimension 8, so \(\Phi \) is an isomorphism. The quaternionic realization and multiplication used here are developed in Hamilton's Quaternions and [voight2021quaternion, sec. 11.2, p. 166].
Taking centers now gives \[ Z\bigl (\mathbb {R}[Q_8]\bigr ) \cong Z\bigl (\mathbb {R}^4\times \mathbb {H}\bigr ) \cong \mathbb {R}^5. \] The comparison is: \[ \begin {array}{c|c|c} \text {object}&\text {retained data}&\text {forgotten data}\\ \hline \mathbb {R}[Q_8]&4\mathbb {R}\text { and }\mathbb {H}&\text {none here}\\ Z(\mathbb {R}[Q_8])&\text {five central factors}& \mathbb {H}\text { and block size or type}. \end {array} \] For a real-centered simple block, the center alone cannot distinguish matrix size or real from quaternionic type. A complex block still has complex center. Hence \(\operatorname {Spec}Z(\mathbb {R}[Q_8])\) is a selected commutative shadow, not a lossless localization of the noncommutative algebra.
Example. isotropy survives the coarse quotient [fgap-000P]AGENTDRAFTED
Example. isotropy survives the coarse quotient [fgap-000P]AGENTDRAFTED
Let \(C_2=\{1,s\}\) act on \(X=\{-1,0,1\}\) by \(s\mathbin {\cdot }x=-x\). The action groupoid \(C_2\ltimes X\) has the points of \(X\) as objects and an arrow \((h,x):x\to h\mathbin {\cdot }x\) for every \(h\in C_2\). Omitting identity arrows, its shape is
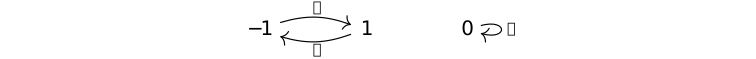
The coarse quotient remembers only the two orbits:

The retained information is already the isotropy arrow in the action groupoid. Passing to its presheaf category organizes families of such data, but does not create that arrow. This test supports the groupoid bridge and does not, by itself, admit a topos layer.
Definition. torsors and the universal torsor [fgap-000Q]AGENTDRAFTED
Definition. torsors and the universal torsor [fgap-000Q]AGENTDRAFTED
Let \(G\) be a group object in a topos \(\mathcal {E}\). A left \(G\)-object \(T\) is a torsor when \(T\to 1\) is an epimorphism and \[ (\mu ,\pi _2):G\times T\longrightarrow T\times T, \qquad (g,t)\longmapsto (g\mathbin {\cdot }t,t) \] is an isomorphism. The second condition is the internal form of freeness and transitivity. See [maclane1992sheaves, sec. VIII.2, pp. 429--430].
For an ordinary group \(G\), write \[ \mathsf {B}G=\mathsf {Set}^{BG^{\mathrm {op}}} \] for the topos of right \(G\)-sets, regarded as presheafs on the one-object category \(BG\). Its universal torsor \(U_G\) has underlying right \(G\)-set \(G\) with regular right multiplication. The constant group object \(\underline {G}\), whose right \(G\)-action is trivial, acts on \(U_G\) by left multiplication. This supplies the torsor action; the left and right actions commute.
For \(C_2\), the regular left action is a torsor in \(\mathsf {Set}\): \[ C_2\times C_2\longrightarrow C_2\times C_2, \qquad (g,h)\longmapsto (gh,h) \] is a bijection. The trivial action on a 2-point set \(D\), despite \(D\to 1\) being onto, is not a torsor. Its corresponding map sends \((g,d)\) to \((d,d)\), so it is neither injective nor surjective. Inhabitation and cardinality alone do not supply a torsor.
Theorem. the classifying property of BG [fgap-000R]AGENTDRAFTED
Theorem. the classifying property of BG [fgap-000R]AGENTDRAFTED
Let \(G\) be a group and \(\mathcal {E}\) a topos over \(\mathsf {Set}\). There is a natural equivalence \[ \operatorname {Geom}_{/\mathsf {Set}}(\mathcal {E},\mathsf {B}G) \simeq \operatorname {Tor}(\mathcal {E},G) \] between geometric morphisms over \(\mathsf {Set}\) to \(\mathsf {B}G\) and \(G\)-torsors in \(\mathcal {E}\). Under this equivalence, a geometric morphism \[ f:\mathcal {E}\longrightarrow \mathsf {B}G \] classifies the torsor \(f^*U_G\).
This is Theorem VIII.2.7 of [maclane1992sheaves]; its theorem and proof are on printed pp. 431--433.
The two directions are visible in the diagram
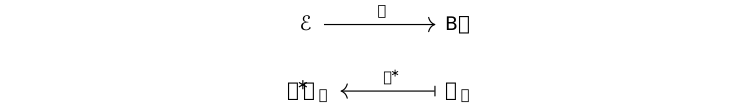
Proof.
Proof.
Inverse image preserves finite limits and, as a left adjoint, colimits. Every epimorphism in a topos is regular, so inverse image carries the universal torsor equations, including the epimorphic map to \(1\), to torsor equations in \(\mathcal {E}\). Conversely, the cited theorem constructs a geometric morphism from a torsor and proves that the two constructions are naturally inverse. The complete construction belongs to the classifying theorem; the point used here is its variance and universal property.
For a single finite action, freeness and transitivity can be checked without topoi. The added value here is one universal object classifying torsors in every topos over \(\mathsf {Set}\) and carrying them along inverse image.
Convention. geometric morphisms and inverse image [fgap-000S]AGENTDRAFTED
Convention. geometric morphisms and inverse image [fgap-000S]AGENTDRAFTED
For a geometric morphism \[ f:\mathcal {E}\longrightarrow \mathcal {F}, \] we write \[ f^*:\mathcal {F}\longrightarrow \mathcal {E}, \qquad f_*:\mathcal {E}\longrightarrow \mathcal {F}, \qquad f^*\dashv f_*. \] Thus the morphism and its inverse-image functor point in opposite directions. The functor \(f^*\) preserves finite limits.
Two examples fix the convention: \[ \begin {array}{c|c|c} \text {input map}&\text {geometric morphism}&\text {inverse image}\\ \hline i:\{x\}\hookrightarrow X& \mathsf {Set}\to \mathsf {Sh}(X)& i^*F=F_x=\displaystyle \varinjlim _{x\in U}F(U)\\[3pt] \varphi :H\to G& \mathsf {B}H\to \mathsf {B}G& \operatorname {Res}^G_H:\mathsf {B}G\to \mathsf {B}H. \end {array} \] In the first row, the stalk is the filtered colimit of all neighborhood sections, not the value on one chosen neighborhood.
Mac Lane and Moerdijk construct inverse-image sheaves through pulled-back étale spaces in [maclane1992sheaves, sec. II.9], especially printed pp. 99--101.
In the second row, right actions are presheaves. Precomposition with \(B\varphi ^{\mathrm {op}}\) is restriction of actions. It has both Kan-extension adjoints, so it is the inverse-image part of the displayed geometric morphism. The homomorphism and geometric morphism point from \(H\) to \(G\); restriction points from \(G\)-objects to \(H\)-objects.
Example. internal inhabitation without a global point [fgap-000T]AGENTDRAFTED
Example. internal inhabitation without a global point [fgap-000T]AGENTDRAFTED
Work in \(\mathsf {B}C_2\), the topos of right \(C_2\)-sets, and let \(U=C_2\) carry the regular right action. The unique equivariant map \(U\to 1\) is an epimorphism because its underlying function is surjective. In the internal language, this says that \(U\) is inhabited. Internal Group Actions are developed in [maclane1992sheaves, sec. V.2, pp. 237--240].
A global element would be an equivariant map \(1\to U\). Its value would have to satisfy \(u\mathbin {\cdot }s=u\), but the regular action has no fixed point. Hence \[ \operatorname {Hom}_{\mathsf {B}C_2}(1,U)=\varnothing . \] The two external tests are: \[ \begin {array}{c|c} \text {internal statement}&\text {external test}\\ \hline U\text { is inhabited}&U\to 1\text { is epi}\\ U\text { has a global point}&U^{C_2}\neq \varnothing . \end {array} \]
More generally, for a nontrivial group \(G\), the regular right \(G\)-object \(U_G=G\) satisfies \[ U_G\to 1\text { is epi}, \qquad \Gamma (U_G)=U_G^G=\varnothing . \] Indeed, if \(xg=x\) for every \(g\), cancellation forces every \(g\) to be \(1\). Internal existence is therefore generalized or local existence; it does not choose a global invariant element. This distinction is not a physical existence claim.
Remark. where the topos layer begins [fgap-000U]AGENTDRAFTED
Remark. where the topos layer begins [fgap-000U]AGENTDRAFTED
The finite tests separate calculations that merely take place in a topos from calculations that use topos-level structure: \[ \begin {array}{c|c|c|c} \text {test}&\text {lower level}&\text {topos value}&\text {verdict}\\ \hline C_3\text { action}&\text {linear action}&\text {none}&\text {fail}\\ C_2\ltimes X&\text {isotropy}&\text {none}&\text {fail}\\ C_2\text { torsor}&\text {free/transitive}&\text {classification}&\text {conditional}\\ \text {context}&\text {pullback/restriction}&\text {inverse image}&\text {conditional}\\ U_G&\text {no fixed point}&\text {internal inhabitation}&\text {strict}. \end {array} \]
Topoi enter these notes only when a result uses universal torsor classification, organizes several constructions as inverse image or base change, or relies on internal reasoning that differs from global sections. Ordinary Group Actions, Group Algebra calculations, and action groupoids stay below that layer.
This boundary also excludes several stronger claims. The spectrum of a center is not the original noncommutative Group Algebra. The action-groupoid example does not require a quotient stack. No site, descent theorem, or physical correspondence has been supplied by these finite tests. Each of those would need its own mathematical construction before extending the present layer.
Models and routes from binary tetrahedral structure [fgap-001F]
📄PDFAGENTDRAFTED
- July 30, 2026
- Utensil Song
Models and routes from binary tetrahedral structure [fgap-001F]
📄PDFAGENTDRAFTED
- July 30, 2026
- Utensil Song
The concrete, internal, external, and abstract models of \(2T\) retain different data. Their comparison opens a Group-Algebra route through the semidirect factors and a representation-theoretic route through the McKay correspondence.
Remark. what the models of 2T retain [fgap-001D]AGENTDRAFTED
Remark. what the models of 2T retain [fgap-001D]AGENTDRAFTED
The same binary tetrahedral symmetry now has several models. They answer different questions.
- The concrete model \(T\leq \mathbb {H}^{\times }\) retains quaternion coordinates, multiplication, conjugation, and norm. It is the model for explicit calculations.
- The internal semidirect-product structure retains the same group \(T\), but also marks the subgroups \(Q,C\leq T\). The facts \[ T=QC,\qquad Q\mathrel {\trianglelefteq }T,\qquad Q\cap C=\{1\} \] say that every element of \(T\) has a unique factorization \(qc\). They expose how the two parts fit inside the concrete group.
- The external model \(Q\rtimes _{\alpha }C\) replaces a quaternion by a pair \((q,c)\). It retains the factors and records their interaction in the conjugation action \(\alpha (c)(q)=cqc^{-1}\). Its multiplication is \[ (q,c)(q',c') =\bigl (q\alpha (c)(q'),cc'\bigr ). \]
- An abstract model can specify the binary tetrahedral group without quaternion coordinates. This is convenient when only its group structure is needed, but coordinates and named factors must be restored by additional maps.
The multiplication map \[ \mu :Q\rtimes _{\alpha }C\longrightarrow T,\qquad (q,c)\longmapsto qc \] is an isomorphism by the internal semidirect-product theorem. Indeed, \[ \mu \bigl ((q,c)(q',c')\bigr ) =q(cq'c^{-1})cc' =qcq'c' =\mu (q,c)\mu (q',c'). \] Thus the external multiplication is not an analogy: it is exactly the concrete multiplication written in factor coordinates. The two carriers are still different, so a theorem or construction passes between them only through an explicit isomorphism. If it refers to the named factors or their action, the transport must also record the corresponding compatibility.
The internal and external constructions are developed in [fre2023discrete, sec. 4.2.13, pp. 62--63] and [isaev2018theory, sec. 1.4.2, pp. 58--61]. The concrete identification of \(2T\) with the Hurwitz unit group and \(Q_8\rtimes \mathbb {Z}/3\mathbb {Z}\) is given in [voight2021quaternion, sec. 11.2.4, p. 168].
Remark. two routes from binary tetrahedral symmetry [fgap-001E]AGENTDRAFTED
Remark. two routes from binary tetrahedral symmetry [fgap-001E]AGENTDRAFTED
The semidirect-product model and the quaternion model open two different routes from the same group. One rewrites the Group Algebra in interacting factor data. The other places the group inside \(\mathrm {SU}(2)\) and leads to the McKay graph.
The Group-Algebra route
The Group-Algebra route
Extend the conjugation action \(\alpha :C\to \operatorname {Aut}(Q)\) linearly to real-algebra automorphisms \[ \overline {\alpha }_c:\mathbb {R}[Q]\longrightarrow \mathbb {R}[Q]. \] On the vector space \(\mathbb {R}[Q]\otimes _{\mathbb {R}}\mathbb {R}[C]\), write a pure tensor as \(a\mathbin {\#}c\) and define \[ (a\mathbin {\#}c)(b\mathbin {\#}d) =a\,\overline {\alpha }_c(b)\mathbin {\#}cd, \] extending bilinearly. This convention defines the skew Group Algebra \(\mathbb {R}[Q]\rtimes _{\overline {\alpha }}C\); it is also a crossed product with trivial twisting cocycle.
The basis map \[ [q]\mathbin {\#}c\longmapsto [qc] \] respects multiplication by the calculation in what the models of 2T retain, and unique factorization makes it a bijection. Hence \[ \mathbb {R}[Q]\rtimes _{\overline {\alpha }}C \mathbin {\cong _{\mathbb {R}\text {-alg}}}\mathbb {R}[T]. \] This is the Group-Algebra form of \(T\cong Q\rtimes _{\alpha }C\). The extension of group maps to Group-Algebra maps follows the convention in [sengupta2010representations, secs. 3.1--3.2, pp. 39--41].
A module over this skew Group Algebra can be read as an \(\mathbb {R}[Q]\)-module \(M\) together with a linear action of \(C\) satisfying \[ c\mathbin {\cdot }(a\mathbin {\cdot }m) =\overline {\alpha }_c(a)\mathbin {\cdot } (c\mathbin {\cdot }m). \] The external model therefore exposes the compatibility needed to assemble representations from the two factors. It does not by itself decompose \(\mathbb {R}[T]\) into simple blocks. That requires further representation-theoretic input.
The McKay route
The McKay route
Under the standard matrix realization of the unit quaternions as \(\mathrm {SU}(2)\), the concrete group \(T\) becomes a finite subgroup of \(\mathrm {SU}(2)\). Let \(\tau _3\) be its faithful 2-dimensional complex representation. The McKay graph has one vertex for each irreducible complex representation \(\tau _i\); the number of edges from \(\tau _i\) to \(\tau _j\) is the multiplicity of \(\tau _j\) in \[ \tau _3\otimes \tau _i. \] For the binary tetrahedral group this graph is the affine Dynkin diagram \(\widetilde {E}_6\). The character table, the seven irreducible representations, and the tensor-product calculation are given in [stekolshchik2008notes, table A.12, prop. A.10, and ex. A.11, pp. 172--174].
This graph connects the representation theory of \(2T\) with quivers and the ADE classification. The same source relates a binary polyhedral subgroup \(G\leq \mathrm {SU}(2)\) to the quotient \(\mathbb {C}^2/G\), its invariant algebra, and its Kleinian singularity in [stekolshchik2008notes, secs. A.3--A.4, pp. 158--161]. These are routes toward quotient geometry and related orbifold constructions. They are not consequences of the semidirect-product theorem alone.
Neither route assigns physical meaning to \(Q\), \(C\), an algebra block, or a vertex of \(\widetilde {E}_6\). They supply mathematical structures on which a physical correspondence could be stated and tested. A proposed correspondence must still identify the action, representation, preserved structure, and physical interpretation.
Methods and search [frap-0005]AGENTDRAFTED
Methods and search [frap-0005]AGENTDRAFTED
Once the constraints are known, a solver still needs a reasoned way to
choose the next move. A solving method organizes a sequence of smaller
goals: at each stage, some information has been fixed and some remains
free. The useful mathematical question is which moves accomplish the next
goal while preserving what has already been achieved. The stabilizer of the
recorded data, as in the general construction
MulAction.stabilizer, gives language to that requirement;
successive stages suggest a chain of subgroups. Conjugation relocates the
effect of a known sequence; commutators can help isolate effects, whose
actual support must be checked in each example. Salkinder uses
conjugates and commutators in the cube setting
[salkinder2021nxnxn, Sections 2 and 3.2].
Explaining why a method works and judging how well it serves a player are related but different tasks. A complete method needs an argument that its stages cover the remaining cases and terminate at a solved state. Practical use also depends on recognition, memorization, and ease of execution. Computational search raises further questions about time, memory, and solution length.
Cayley graphs describe move sequences as paths between group
elements [pan2021fourier, Section 4, Definition 4]; actions on
partial information lead to Schreier graphs. The generic labeled-edge
construction is Quiver.SchreierGraph: a move labels an edge
from a state to its image. For the left action of a group on itself,
this is the Cayley viewpoint. These declarations supply stabilizers
and action graphs; they do not establish a puzzle-solving method.
Such descriptions become useful when comparing reduction
strategies or searching for shorter sequences. Any length comparison
must specify the allowed moves and their costs. The goal is to connect
a method's observable effect with its mathematical explanation.
Scrambling and search functions describe a related use
of functions on the move group. The complete layer-first construction is
given in a complete layer-first method, while computer
solving and efficiency turns these graphs into exact searches,
lower bounds and subgroup reductions. This chapter keeps the method next
to the graph and stabilizer language needed to analyze it.
Scrambling, spectra and search coordinates [frap-0015]AGENTDRAFTED
Scrambling, spectra and search coordinates [frap-0015]AGENTDRAFTED
Random moves raise a different question from solving: when, and how quickly, does a scramble lose information about its starting state? A random walk depends on its allowed moves and their probabilities. We use the fixed-frame three-layer move group from the complete cube account, and write \(G\) for its reachable state group. A walk with step law \(\mu \) has distribution
\[\Pr [X_k=g]=\mu ^{*k}(g)\]from the solved state, where convolution records the successive moves.
A parity calculation before mixing claims
A parity calculation before mixing claims
Let \(\varepsilon :G\to \{+1,-1\}\) be the sign of the corner permutation. Each face quarter-turn or inverse is a four-cycle on corners, so \(\varepsilon =-1\); each face half-turn is a product of two transpositions, so \(\varepsilon =+1\). If the walk chooses uniformly from the twelve quarter-turns and inverse quarter-turns, then
\[\varepsilon (X_k)=(-1)^k\]with probability one. Its support is therefore contained in one parity coset at every fixed time, while the uniform distribution on \(G\) gives equal mass to the two cosets. The total-variation distance from uniform is at least \(1/2\) for every \(k\). This walk cannot converge to uniform: the obstruction is periodicity, not a slow estimate of a mixing time.
The usual eighteen-move HTM law gives a different exact observable. Six half-turns have sign \(+1\) and twelve quarter-turns or inverses have sign \(-1\), hence one step has
\[\mathbb E[\varepsilon (X_1)]=\frac 6{18}-\frac {12}{18}=-\frac 13.\]Independence gives \(\mathbb E[\varepsilon (X_k)]=(-1/3)^k\). Since uniform parity has expectation zero, the parity marginal alone gives the lower bound
\[\lVert \mathcal L(X_k)-\mathcal U_G\rVert _{\mathrm {TV}}\geq \frac 12\left (\frac 13\right )^k.\]This bound decays and does not prove convergence by itself. A lazy walk, which includes the identity with positive probability, removes this specific periodicity; a convergence statement still needs a generated reachable component and an aperiodicity argument.
Averaging and finite-group spectra
Averaging and finite-group spectra
For a function \(f:G\to \mathbb C\), the one-step averaging operator is
\[(T_\mu f)(g)=\sum _{s\in G}\mu (s)f(gs).\]Constants are fixed by \(T_\mu \). For a finite-dimensional unitary representation \(\rho \), its matrix coefficients
\[f_{u,v}(g)=\langle u,\rho (g)v\rangle \]form invariant blocks for this operator: averaging a coefficient replaces \(\rho (g)\) by multiplication by the Fourier block
\[\widehat \mu (\rho )=\sum _{s\in G}\mu (s)\rho (s).\]Thus the nonconstant spectrum describes which observables retain memory. If the step support generates the reachable group and every nontrivial block contracts on the relevant quotient, then these blocks decay and the walk converges to uniform on that component. The hypotheses matter: the quarter-turn walk above fails the aperiodicity test, so no spectral slogan can erase its parity obstruction.
The same calculation explains why a prescribed scramble length is not a universal guarantee of randomness. A distance bound answers how far a state can be from solved; a distributional claim asks how the whole law projects onto every persistent observable. These are different certificates.
Fourier coordinates for learned search
Fourier coordinates for learned search
Pan and Kondor use irreducible-representation matrix coefficients as a Fourier basis for learned value functions on permutation puzzles [pan2021fourier, Sections 4--4.1]. Their experiments compare learned scores that choose moves with conventional heuristic and value-based search; the paper explicitly discusses the distinction from an admissible lower bound [pan2021fourier, Section 6]. A learned score can rank promising moves while overestimating or underestimating the remaining distance. It is therefore evidence about search guidance, not a shortest-path certificate.
For the cube, a safe lower bound can still be obtained from the exact projected distances in a pattern database as in computer solving and efficiency. A Fourier score may be combined with that bound as a tie-breaker or move-ordering device, but replacing the bound with the score changes the guarantee. The representation coordinates explain how a search function is organized; they do not, without an error theorem, make it admissible.
The displayed parity bounds and finite-operator framework are the results established here. They do not claim a full-cube mixing time, a universal scramble length, or a reproduced machine-learning benchmark. Those would require a declared move law, reachable component, statistical or spectral analysis, and independently checked computational evidence.
Status [spin-000S]
Status [spin-000S]
Currently it's a work-in-progress.
The complete three-layer cube [frap-0016]AGENTDRAFTED
The complete three-layer cube [frap-0016]AGENTDRAFTED
The all-size law has two reasons to be followed by a separate three-layer account. A \(3\times 3\times 3\) cube has no moving centers or coupled edges, and its familiar three tests can be checked directly on the six outer-face generators. We use the fixed local frame convention and keep the global viewing frame fixed. Unmarked centers give the following coordinate record.
\[(\sigma ,x;\tau ,z)\in S_8\times (\mathbb Z_3)^8 \times S_{12}\times (\mathbb Z_2)^{12}.\]Here \(\sigma \) and \(\tau \) record corner and edge positions. The corner local frame uses the U/D sticker to record a twist in \(\mathbb Z_3\); an edge local frame uses the U/D or F/B sticker convention to record a flip in \(\mathbb Z_2\). The six centers fix the frame but have no recorded orientation. This is the ordinary cube model, rather than a supercube model with marked centers.
Generators and the three obstructions
Generators and the three obstructions
Write \(R,L,U,D,F,B\) for clockwise quarter-turns as seen from the corresponding face; inverses and squares are allowed. Each turn is a four-cycle on corners and a four-cycle on edges. Thus it changes both permutation signs, leaving
\[\operatorname {sgn}(\sigma )=\operatorname {sgn}(\tau )\]unchanged. A turn of U or D changes no corner twist in this convention; a turn of another face adds one and subtracts one at opposite corners. The four affected edge frames change in pairs. Consequently every reachable state satisfies
\[\sum _{i=1}^{8}x_i=0\pmod 3,\qquad \sum _{j=1}^{12}z_j=0\pmod 2.\]These checks are generator checks, so they also cover inverses, powers and arbitrary words. They give immediate impossible states: one twisted corner has corner sum \(1\); one flipped edge has edge sum \(1\); and a swap of two corners alone has odd corner sign but even edge sign. A state can pass all three tests and still require a construction; necessity is not sufficiency. The coordinate convention and invariant calculation agree with the 3-layer case of [salkinder2021nxnxn, Theorems 8--18].
Localized effects and sufficiency
Localized effects and sufficiency
We now describe a constructive cleanup. Let \([a,b]=aba^{-1}b^{-1}\) and \([a:b]=aba^{-1}\). The word
\[c=[[R:U],D]\]is a three-cycle on corners and fixes the other corner positions. A direct coordinate replay gives this cycle; conjugating by face turns moves it through the connected corner orbit. Hence these conjugates generate \(A_8\). For edges, the outer-turn word
\[e=R\,U^{-1}\,R\,U\,R\,U\,R\,U^{-1}\,R^{-1}\,U^{-1}\,R^2\]is a three-cycle on three edges and fixes the corners (the familiar U-permutation). Conjugates generate \(A_{12}\). The displayed words are useful witnesses, not a claim that they are short in every metric.
Given a state satisfying the sign equation, apply one face turn when the common sign is odd. The remaining corner and edge permutations are even. Use the conjugated corner cycles to clear \(\sigma \), then the conjugated edge cycles to clear \(\tau \); each cleanup is chosen in the subgroup that fixes the already-cleared piece type. The sign equation is exactly what makes both cleanups possible.
After positions are restored, the orientation kernels are generated by local commutators. The standard corner trigger \((R^{-1}D^{-1}RD)^2\) restores positions while twisting two corners in opposite directions; setup, trigger, and inverse setup transport this effect to any pair. For edges, the local trigger \(F R U R^{-1}U^{-1}F^{-1}\) is combined with its conjugate and inverse setup to give a pure two-edge flip. A direct sticker replay checks that support and the two flipped signs. Their transported effects generate the kernels
\[\ker ((\mathbb Z_3)^8\to \mathbb Z_3)\quad \text {and}\quad \ker ((\mathbb Z_2)^{12}\to \mathbb Z_2).\]The two displayed sums are therefore the only orientation obstructions. Reversing the cleanup word reaches every tuple satisfying the three tests. This is a constructive subgroup argument; it does not identify a shortest solution.
Count and a worked reachability check
Count and a worked reachability check
There are \(8!\) corner permutations, \(12!\) edge permutations, \(3^8\) raw corner orientations and \(2^{12}\) raw edge orientations. The sign equation removes a factor of two, and the two orientation sums remove factors of three and two. Thus the number of labelled reachable states is
\[8!\,12!\,3^7\,2^{10} =43\,252\,003\,274\,489\,856\,000.\]For a concrete reachability check, start from solved and apply the corner cycle \(c\). Its corner permutation is a 3-cycle, its edge permutation is the identity, and its orientation sums remain zero, so it passes every test. Applying \(c^{-1}\) returns to solved. More generally, the cleanup above factors any passing state into a sign correction, even corner and edge permutations, and orientation-pair operations; this gives an explicit solve word once the required cycles and setup positions have been selected.
Unmarked centers explain why a whole-cube rotation is not counted as a generator and why the center colors fix a frame rather than add twelve more coordinates. The all-\(N\) chapter keeps these choices visible when moving centers and coupled edges return. The next chapters can now discuss human methods and computer search using this completely specified 3-layer action.
The family of layered cubes [frap-0003]AGENTDRAFTED
The family of layered cubes [frap-0003]AGENTDRAFTED
To pass from one cube size to another, we first fix a physical model. Let \(C_N\) be an \(N\times N\times N\) array of physical units, and call each unit a cubie. Give the units coordinates \((i,j,k)\in {1,...,N}^3\). A visible cubie is a surface cell, so at least one coordinate is \(1\) or \(N\). A cell with three boundary coordinates is a corner; with exactly two it is an edge; with exactly one it is a center. This is a description of positions, before we decide which labels a player can see.
The resulting counts are immediate: there are \(8\) corners, \(12(N-2)\) edge cubies, and \(6(N-2)^2\) center cubies. Their sum is the number of surface cells. The count already explains why changing \(N\) is more than making a larger drawing. New edge and center positions appear, and those positions can fall into different move orbits. Bonzio, Loi and Peruzzi use this cubie decomposition in their general model [bonzio2018nxnxn, Sections 2--3]; Salkinder gives a parallel orbit and configuration analysis [salkinder2021nxnxn, Section 2].
The abstract-to-cube handoff is made explicit in how the cube models connect. In the \(N=3\) case, the 54 facet-colored incidence positions group into corner and edge sticker fibers, with six fixed centers supplying the frame; the resulting action is the coordinate model in the global viewing frame used later. For larger \(N\), the new center and coupled-edge orbits prevent this from being a single ordinary-cube coordinate space.
Layer turns and the global viewing frame
Layer turns and the global viewing frame
Choose the six coordinate directions as a global viewing frame. For an axis \(a\in {x,y,z}\), a depth \(r\) with \(1\le r\le \lfloor N/2\rfloor \), and either boundary of that axis, turn the layer \(a=r\) or \(a=N+1-r\) by a quarter-turn. The turn rotates the other two coordinates and carries every sticker on a moved cubie with it. For odd \(N\), the central layer is deliberately omitted; this is the usual fixed-center convention. Thus \(N=3\) has the six outer-face turns, while \(N=4\) has the outer and adjacent inner layers.
This choice distinguishes a layer turn from a whole-cube rotation. Whole-cube rotations change the chosen frame and are not generators of the state group here. They can be added as a separate symmetry action, or used to identify observations later. Keeping them out makes the six face directions, and hence a fixed center color scheme, part of the state description.
A labelled state assigns a distinct name to every physical cubie and, when needed, to every sticker. A move acts by permuting these labels and their local frames. An ordinary colored observation forgets distinctions between equal-colored stickers; a marked or 'supercube' observation retains them. These are different quotients of the same labelled action. In particular, a statement that two center cubies 'look the same' is an observation claim, not a claim that the labelled pieces are interchangeable by a move.
The coordinate signatures of the orbits
The coordinate signatures of the orbits
The useful invariant is the distance of a coordinate from the nearest boundary. A layer turn permutes two coordinates, possibly changes their signs relative to the cube center, and leaves the multiset of these distances unchanged. It therefore preserves corners, edges and centers. On an edge, the one nonboundary coordinate gives a ring index. On a center, the two interior coordinates give an unordered pair of distances. Equal distances give a center-corner position in a concentric ring; unequal distances give a center-edge position. The central pair in an odd cube is the fixed center.
Write \(K_e=N/2-1\) for even \(N\) and \(K_o=(N-3)/2\) for odd \(N\). The position orbits under the selected layer turns have the following sizes. For even \(N\), the coupled-edge orbits \(E_1,...,E_{K_e}\) each have \(24\) positions. For odd \(N\), there is a single-edge orbit \(E_s\) of size \(12\), together with coupled-edge orbits \(E_1,...,E_{K_o}\) of size \(24\) each. The term coupled records that the edge is away from the odd cube's middle edge position; it does not by itself choose an orientation convention.
For even \(N\), each center-corner ring \(C_k\), \(1\le k\le K_e\), has \(24\) positions. The center-edge ring \(D_k\), \(2\le k\le K_e\), has \(48(k-1)\) positions, split into \(2(k-1)\) distinct orbits of \(24\). For odd \(N\), there are \(6\) fixed centers, center-corner rings \(C_k\) of size \(24\), and center-edge rings \(D_k\) of size \(24(2k-1)\), each for \(1\le k\le K_o\). Each odd ring is likewise a union of \(2k-1\) orbits of \(24\). Summing these rows gives \(6(N-2)^2\) centers in both parities. The formulas expose the distinction between a position orbit and an orientation coordinate: a one-sticker center has no orientation unless it is specially marked, while a coupled edge can have a convention-dependent orientation record.
These sets are not merely a count. Face turns carry a representative edge around the four faces of its ring; an inner layer at depth \(k\), conjugated by outer turns, carries it to the other axis directions. The same construction carries a center-corner representative around its ring and a center-edge representative around every position with the same ordered distance-pair or chirality label. Hence each displayed \(24\)-position set is a move orbit, while the distance signature proves that different rows cannot mix. This is the coordinate part of the model; legality constraints on the permutations are a separate question.
Small cubes make the parity split visible
Small cubes make the parity split visible
For \(N=2\), \(K_e=0\): there are only the eight corners. For \(N=3\), \(K_o=0\): the pieces are eight corners, twelve single edges and six fixed centers. This is the familiar cube, but the description explains why its centers do not move in the chosen layer family.
For \(N=4\), \(K_e=1\): there are eight corners, one coupled-edge orbit of \(24\), and one center-corner orbit of \(24\); there are no fixed centers and no center-edge ring. For \(N=5\), \(K_o=1\): there are eight corners, twelve single edges, one coupled-edge orbit of \(24\), six fixed centers, one center-corner orbit of \(24\), and one center-edge orbit of \(24\). The latter has \(8+36+54=98\) visible cubies, the familiar Professor's Cube count. These examples show what changes with parity without claiming that the same labels or orientation coordinates are used by every source.
The ordinary cube action is the \(N=3\) outer-layer case of this model. The next chapter can therefore state constraints for a fixed three-layer convention, while the all-\(N\) first law must still reconcile the labelled, colored and coupled-edge conventions in Bonzio--Loi--Peruzzi and Salkinder. Salkinder writes all slice rotations, including a central slice in odd size, and then treats its use through a shifted middle-slice convention; this is a genuine convention choice, not a harmless notation change. We use the fixed-center generators above and leave the translation between these move families explicit. The first law records the invariant equations with a source-backed sufficiency sketch; the full constructive convention transfer remains a separate proof obligation.
The first law for the layered cube [frap-0004]AGENTDRAFTED
The first law for the layered cube [frap-0004]AGENTDRAFTED
The layered model needs a reachability test. A tuple of permutations and orientations can describe a dismantled cube without being obtainable by legal slice turns. We now choose the labelled, fixed-frame state space from the layered-cube model and state the first law for that space. The theorem is a statement about labelled cubies; an ordinary colour pattern is its observation after equal-looking labels have been forgotten.
Coordinates for one state space
Coordinates for one state space
Let \(K_o=(N-3)/2\) for odd \(N\) and \(K_e=N/2-1\) for even \(N\). For every cube there are a corner permutation \(\sigma \in S_8\) and corner orientation vector \(x\in (\mathbb Z_3)^8\). For odd \(N\), there is also a single-edge permutation \(\tau _s\in S_{12}\) and flip vector \(z\in (\mathbb Z_2)^{12}\). Each coupled-edge orbit indexed by \(i\in I\) has a permutation \(\tau _i\in S_{24}\) and a labelled orientation vector \(y_i\in (\mathbb Z_2)^{24}\). Each center-corner orbit has a permutation \(\rho _i\in S_{24}\). Center-edge orbits are indexed by a finite set \(J\); write \(\rho _{ij}\) for the orbit whose two distance signatures are \(i,j\). In the fixed-center convention, \(I=\{1,\ldots ,K_o\}\) and \(J=I^2\) when \(N\) is odd, while \(I=\{1,\ldots ,K_e\}\) and \(J=\{(i,j)\in I^2:i\ne j\}\) when \(N\) is even. This indexing records which coupled-edge signatures border a center-edge orbit; it is the coordinate version of the rings in the preceding chapter.
The full labelled configuration space is the product of these factors, with the solved state represented by identity permutations and zero orientation vectors. It is deliberately larger than the move group. For example, a vector \(y_i\) records all sticker orientations allowed by a labelled reassembly, even though the legal slice action fixes the relevant coupled-edge orientation in its orbit. Whole-cube rotations are still outside the generator set, and the six face directions remain part of the frame.
The invariant law
The invariant law
For odd \(N\), a configuration is legal exactly when
\[\begin {aligned} \operatorname {sgn}(\sigma )&=\operatorname {sgn}(\tau _s)= \operatorname {sgn}(\rho _i) &&(i\in I),\\ \operatorname {sgn}(\rho _{ij})&=\operatorname {sgn}(\sigma ) \operatorname {sgn}(\tau _i)\operatorname {sgn}(\tau _j) &&((i,j)\in J),\\ \sum _r x_r&=0\pmod 3,\qquad \sum _r z_r=0\pmod 2,\\ y_i&=0 &&(i\in I). \end {aligned}\]For even \(N\), the corresponding law is
\[\begin {aligned} \operatorname {sgn}(\sigma )&=\operatorname {sgn}(\rho _i) &&(i\in I),\\ \operatorname {sgn}(\rho _{ij})&=\operatorname {sgn}(\sigma ) \operatorname {sgn}(\tau _i)\operatorname {sgn}(\tau _j) &&((i,j)\in J),\\ \sum _r x_r&=0\pmod 3,\\ y_i&=0 &&(i\in I). \end {aligned}\]The empty-index cases are part of the statement: \(N=2\) has only corners, \(N=3\) has the usual twelve single edges and fixed centers, and \(N=4\) has one coupled-edge and one center-corner orbit but no center-edge orbit. The \(N=5\) instance has one orbit of each coupled-edge, center-corner and center-edge type, giving the 98 visible cubies counted earlier.
Necessity follows by checking generators. An outer face turn is a 4-cycle on corners, single edges, center corners and each relevant center-edge orbit, and two 4-cycles on each affected coupled-edge orbit. An inner slice turn is the identity on corners and single edges, and is a 4-cycle on its coupled edges and on the matching center-edge orbits, with two 4-cycles on center corners. These cycle signs give the two parity rows. The corner character changes by two opposite units on a non-\(U\)/\(D\) face and not at all on a \(U\)/\(D\) face, so its sum is fixed modulo 3. An outer turn flips four single edges, so their sum is fixed modulo 2. The chosen coupled-edge sticker convention makes every legal \(y_i\) zero. The solved state satisfies the rows, hence every word in the generators does.
Bonzio--Loi--Peruzzi give the labelled Professor's-Cube version of the same tuple and its corrected coupled-edge condition [bonzio2018nxnxn, Theorem 5]. Salkinder states the odd and even families and checks these generator effects in [salkinder2021nxnxn, Theorems 8--9]. Their notation indexes center-edge orbits by the two adjacent coupled-edge signatures; our \(J\) makes that indexing explicit. The sources also use a shifted notation for a middle slice when constructing a single-edge 3-cycle. That auxiliary word is a composition of parallel slice turns in the fixed-center model; it does not add a central generator to the law above.
What the cited theorem supplies
What the cited theorem supplies
Salkinder's Theorems 10--18 supply the sufficiency direction after the position orbits, orientation conventions and parity rows have been fixed [salkinder2021nxnxn, Theorems 10--18]. We use that result here as a source-backed proof sketch. The source construction combines parity correction with 3-cycle generation on each position orbit, then uses commutators to generate the two orientation kernels. Its theorem sequence supplies the orbit-specific words and their effects; the displayed equations are the conditions transported into the coordinate conventions of this note.
- The corner and single-edge factors are reduced by the source's parity-correction words and orbit 3-cycles, giving the alternating groups required by the corresponding parity rows.
- The center-corner, center-edge and coupled-edge factors are handled by the analogous orbit-specific commutators and their conjugates. The coupled-edge orientation factor remains zero in the fixed sticker convention.
- After the permutation factors are cleared, the source's opposite corner twists and edge-flip commutators generate the kernels of the corner-sum and single-edge-sum maps. The displayed orientation rows are therefore exactly the residual conditions in this coordinate summary.
This is a source-backed proof sketch, not a self-contained constructive proof in the present notation. In particular, the symbols for source moves, orbit representatives, induced effects and kernel-generation words are not redefined here. A complete independent construction would require typed definitions, convention conversion and effect calculations for each such word. Those details are supplied by the cited source theorem sequence, rather than asserted by this summary. The argument is consequently a subgroup-generation result, not a claim that one universal short algorithm solves every size.
There are two boundaries to keep visible. The theorem concerns labelled positions and a fixed frame; a colour-only observation quotients by equal labels and may identify several legal labelled states. Also, Bonzio's and Salkinder's orbit labels are source conventions, so a numerical state count must be transported through the index sets before comparison. The next three-layer chapter specializes the same action to \(N=3\), where all center and coupled-edge factors disappear and the three familiar constraints can be worked through with explicit face generators.
Which moves survive a quotient? [frap-0019]AGENTDRAFTED
Which moves survive a quotient? [frap-0019]AGENTDRAFTED
A quotient of observations is useful only when the moves still have a well-defined action on the observations. Let \(X\) be a declared sticker state set, let \(G\) act on \(X\), and let the surjection \(q:X\twoheadrightarrow Y\) identify the observations we want to retain (equivalently, take \(Y=q(X)\)). The move \(g\in G\) preserves the fibers of \(q\) when
\[q(x)=q(x')\Longrightarrow q(gx)=q(gx')\qquad (x,x'\in X).\]Exactly in this case there is a unique induced map \(\bar g:Y\to Y\) with
\[q\circ g=\bar g\circ q.\]If \(g\) is a bijection and \(X\) is finite, then \(\bar g\) is surjective and therefore bijective. In an infinite setting, require the inverse move to preserve fibers as well. Thus, for the finite cube action below, the fiber-preserving bijections form a subgroup; a quotient does not automatically inherit the whole puzzle action.
The antipodal sticker quotient
The antipodal sticker quotient
For the ordinary cube, use the surface-cell and local frame convention in how the cube models connect and the complete three-layer cube. Represent a sticker in the sticker state by a pair \((p,n)\), where \(p\in \{-1,0,1\}^3\) satisfies \(\lVert p\rVert _\infty =1\) and \(n=\operatorname {sgn}(p_i)e_i\) for each nonzero coordinate \(p_i\). Thus corners, edges and face centers contribute \(8\cdot 3\), \(12\cdot 2\) and \(6\cdot 1\) pairs, respectively, for 54 stickers. The antipodal identification is the involution
\[a(p,n)=(-p,-n),\qquad q(p,n)=\{(p,n),a(p,n)\}.\]Its sticker fibres pair opposite stickers. This is a quotient of the sticker state action on labelled stickers; it is not the same as forgetting equal colors or quotienting by whole-cube rotations.
Why one face turn fails
Why one face turn fails
The positive-\(z\) face turn uses
\[u(x,y,z)=(y,-x,z)\]on every sticker whose cubie has \(z=1\), rotating both its position and its normal, and fixes the other cubies. Take a top sticker and its antipode, for example
\[x=((1,1,1),e_z),\qquad a(x)=((-1,-1,-1),-e_z).\]The turn sends \(x\) to the sticker at \(((1,-1,1),e_z)\), while it fixes \(a(x)\). These outputs are not an antipodal pair, so \(q(ux)\ne q(u\,a(x))\). The single \(U\) move therefore does not descend to the antipodal quotient.
A synchronized opposite-layer move
A synchronized opposite-layer move
The clockwise turn of the negative-\(z\) face, viewed from that face, is the inverse global rotation on \(z=-1\). Write it as \(d\); its inverse \(d^{-1}\) uses the same global rotation as \(u\). The composite \(u d^{-1}\) rotates both opposite layers by the same linear map and fixes the middle cubies. It commutes with the antipodal involution:
\[a\,(u d^{-1})=(u d^{-1})\,a.\]Consequently it preserves every antipodal fiber and induces a bijection on \(Y\). A direct check of all 54 stickers gives the same result: \(U\) fails on the displayed pair, while the synchronized \(U D'\) move maps every antipodal pair to an antipodal pair. The surviving action is therefore an action of the fiber-preserving subgroup, not of the six ordinary face turns individually.
What the cover does not provide
What the cover does not provide
A covering or quotient of the underlying shape supplies a map of shape data. It does not by itself supply a map between sticker-state spaces, a chosen fiber relation, or an equivariance proof for each legal move. Those data are separate: the explicit cube action records which stickers a face turn moves, while the quotient records which states are identified. A move descends only after the displayed fiber test has been checked.
This is the precise limit of the comparison with the complete unfolding in label transport and topology. Projectivity and branched unfolding describe transport of simplex labels; the antipodal example describes descent of a particular sticker action. They pose analogous questions about information lost by identification, but neither construction is being identified with the other. A general lifting or descent classification is outside this note.
The practical rule is short: state the state space, the quotient map and the move action before saying that a move survives identification. The antipodal calculation supplies both a negative and a positive finite example, while preserving the distinction between a shape cover and a compatible puzzle action.