Example. The split four-dimensional Spin action is left and inverse-right multiplication [fcap-003Y]
AGENTDRAFTED
For \(Q_{2,2}(v)=v_0^2+v_1^2-v_2^2-v_3^2\), the even
Clifford algebra is a pair of real matrix algebras. We construct its
coordinates to specify which Spin factor acts on each side of a vector.
Set \(A=e_0e_1\), \(B=e_0e_2\), \(C=e_1e_2\), and \(I=e_0e_1e_2e_3\).
The subalgebra \(H_0=\langle 1,A,B,C\rangle _{\mathbb R}\) has
\(A^2=-1\), \(B^2=C^2=1\), and \(AB=-C\). Define
\[J=\begin {pmatrix}0&1\\-1&0\end {pmatrix},\quad
S=\begin {pmatrix}0&1\\1&0\end {pmatrix},\quad
D=\begin {pmatrix}-1&0\\0&1\end {pmatrix}.\]
The assignments \(\rho (A)=-J\), \(\rho (B)=D\), \(\rho (C)=S\)
satisfy these relations and give a basis of \(M_2(\mathbb R)\) together
with the identity. They define an algebra equivalence \(\rho \).
The volume element \(I\) is central in the even algebra and \(I^2=1\).
The eight even basis monomials give
\(\mathcal {C}\kern -2pt\ell ^+(Q_{2,2})=H_0\oplus I H_0\). Hence the map
\[\Phi (u+Iw)=\bigl (\rho (u)-\rho (w),\ S(\rho (u)+\rho (w))S\bigr )\]
is an algebra equivalence to \(M_2(\mathbb R)\times M_2(\mathbb R)\).
For a pair \((P,R)\), its inverse is recovered from
\[\rho (u)=\tfrac 12(P+SRS),\qquad
\rho (w)=\tfrac 12(SRS-P).\]
The reversion fixes \(I\) and negates
\(A,B,C\). On \(H_0\), this is matrix adjugation, since \(\rho (A),
\rho (B),\rho (C)\) are traceless. Conjugation by \(S\) commutes with
adjugation, so
\[\Phi (\operatorname {rev}(x))=
\bigl (\operatorname {adj}(\Phi _1(x)),
\operatorname {adj}(\Phi _2(x))\bigr ).\]
Consequently \(\operatorname {rev}(x)x=1\) if and only if both component
determinants are one. The carrier lemma Lemma [fcap-002J] therefore
restricts \(\Phi \), with the displayed inverse, to the actual group
\[\operatorname {Spin}(Q_{2,2})\simeq SL_2(\mathbb R)\times SL_2(\mathbb R).\]
Porteous's norm-one subgroup is denoted \(\operatorname {Spin}^+\);
his split-four entry is a pair of \(Sp_2(\mathbb R)\) factors
[porteous1995clifford, Chapter 17, Theorem 17.9 and Table 14, p. 159].
In degree two, \(M^{\mathsf T}JM=(\det M)J\), so these are precisely
\(SL_2(\mathbb R)\). The norm-one restriction is essential to that comparison.
Our pair map has the following six bivector images:
\[\begin {aligned}
e_0e_1&\longmapsto (-J,J),& e_0e_2&\longmapsto (D,-D),\\
e_0e_3&\longmapsto (-S,S),& e_1e_2&\longmapsto (S,S),\\
e_1e_3&\longmapsto (D,D),& e_2e_3&\longmapsto (-J,-J).
\end {aligned}\]
In particular \(\Phi (I)=(-1,1)\). These are the specializations of
TauCeti's bilinear-generator formula
TauCeti.realCliffordTwoTwoEvenEquivMatrixProd_ι.
Since the bivectors generate the even algebra, this identifies \(\Phi \)
with its concrete even-algebra map and hence identifies the restricted
group equivalence
TauCeti.realSpinTwoTwoEquivSpecialLinearProd.
Now encode vectors by
\[X(v)=\Phi _1(ve_3)S=
\begin {pmatrix}-v_0-v_2&-v_1-v_3\\v_1-v_3&-v_0+v_2\end {pmatrix}.\]
The inverse sends \(\begin {pmatrix}a&b\\c&d\end {pmatrix}\) to
\((-(a+d)/2,(c-b)/2,(d-a)/2,-(b+c)/2)\). A determinant expansion gives
\(\det X(v)=Q_{2,2}(v)\). Thus \(X\) identifies the whole vector space
with the determinant quadratic space of real two-by-two matrices
TauCeti.realCliffordTwoTwoVectorEquivMatrix_apply
TauCeti.realCliffordTwoTwoVectorEquivMatrix_det.
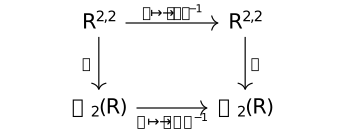
Writing \(\Phi (s)=(P,R)\) for a Spin element, the action is
\[X(svs^{-1})=P X(v)R^{-1}.\]
For the proof, \(e_3^2=-1\), and conjugation
\(\gamma (x)=-e_3xe_3\) fixes \(H_0\) and negates \(I\). Therefore
\[\Phi (\gamma (x))=
\bigl (S\Phi _2(x)S,\ S\Phi _1(x)S\bigr ).\]
The identities
\[e_0e_3=IC,\qquad e_1e_3=-IB,\qquad e_2e_3=-IA\]
give the displayed formula for \(X\). Apply \(\Phi _1\) to
\((svs^{-1})e_3=s(ve_3)\gamma (s^{-1})\), then multiply on the right
by \(S\). Since \(S^2=1\), the result is \(P X(v)R^{-1}\).
This proves TauCeti's exact coordinate action
TauCeti.realSpinTwoTwoEquivSpecialLinearProd_action.
The diagram records the two ways to calculate the same action:
 For example, take \(P=\operatorname {diag}(a,a^{-1})\), \(R=1\),
where \(a\ne 0\). The two rows of \(X(v)\) are multiplied by \(a\)
and \(a^{-1}\). Thus the null cone is exactly the matrices of rank at
most one, and its rank-one part is preserved. For \(P=R\), the matrix
\(X(e_0)=-1\) is fixed; this diagonal subgroup fixes \(e_0\).
As in the compact action of Example [fcap-003K], multiplication by a
fixed vector makes an odd vector accessible to the even algebra, and
conjugation by that vector interchanges its two factors. Here the factors
are real matrices, with the explicit \(S\)-conjugations above. This is
the even-algebra action transport of
[porteous1995clifford, Chapter 16, Proposition 16.9, pp. 143--144]
in the stated axes. The construction gives the group and its vector
action; its orthogonal image retains the spinor-norm qualification
of Theorem [fcap-0023].
Definition [ca-000J]Definition [ca-001J]Definition [spin-0012]Definition [spin-000O]